WO2022012155A1 - 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 - Google Patents
一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 Download PDFInfo
- Publication number
- WO2022012155A1 WO2022012155A1 PCT/CN2021/094741 CN2021094741W WO2022012155A1 WO 2022012155 A1 WO2022012155 A1 WO 2022012155A1 CN 2021094741 W CN2021094741 W CN 2021094741W WO 2022012155 A1 WO2022012155 A1 WO 2022012155A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- equation
- inverted pendulum
- robust
- iterative learning
- matrix
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B13/00—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion
- G05B13/02—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric
- G05B13/04—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric involving the use of models or simulators
- G05B13/042—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric involving the use of models or simulators in which a parameter or coefficient is automatically adjusted to optimise the performance
Definitions
- the invention relates to the field of iterative learning control, in particular to a limited frequency range robust iterative learning control method of a series inverted pendulum.
- the series inverted pendulum is a high-order, strong coupling, multi-variable unstable and complex system, which can intuitively respond to control problems such as nonlinearity, stability and robustness, and is a good device for testing control theory.
- the series inverted pendulum is composed of several inverted pendulum subsystems with the same structure in series, and the inverted pendulum subsystem has an important engineering application background.
- the stability control of single-stage inverted pendulum is widely used in attitude control during rocket flight.
- the inverted pendulum is similar to the walking of a biped robot. In daily life, the problems of the center of gravity on the top and the fulcrum on the bottom are very similar to the inverted pendulum.
- the stability control has a wide range of practical applications, such as the stability control of offshore drilling platforms, the stability control of satellite launchers, and the stability control of rockets. Attitude control, safe landing of aircraft, chemical process control, etc. Therefore, the series inverted pendulum composed of several inverted pendulum subsystems has a good engineering application background.
- control methods for the series inverted pendulum mainly include: expert control, fuzzy control and neural network control.
- the main body of expert control is composed of knowledge base and reasoning mechanism, which involves automatic update of knowledge base and automatic rule generation. Therefore, expert control has great limitations in real-time and parallel processing of information. Fuzzy control has strong robustness and fault-tolerance performance, but because of its fuzzy characteristics, the control precision and dynamic quality of the system will be reduced.
- Neural network control has strong adaptive ability, but it must have known specific engineering application data samples, and it also needs a long enough time for online or offline learning and training, so its convergence speed is slow. The above control methods have great limitations in the real-time performance and accuracy of the system, and it is difficult to solve the trajectory tracking problem of the series inverted pendulum.
- the present inventor proposes a robust iterative learning control method with a limited frequency range of a series inverted pendulum.
- the repeated operation of the multi-dimensional series inverted pendulum system is converted into an equivalent system, and then in order to further express the connection between the bounded disturbance and the system output error, a robust iterative learning control law is designed to convert the controlled system into a class of continuous Discrete Repeating Process Model.
- a robust iterative learning control algorithm is represented by linear matrix inequalities. The proposed algorithm will ensure that the system is stable in the frequency domain and has robust control performance, and at the same time ensures the convergence of the output error in the time and frequency domains in the presence of external disturbances.
- a limited frequency range robust iterative learning control method for series inverted pendulums comprising the following steps:
- the first step establish the state space equation of the series inverted pendulum
- k represents the iteration period
- p represents the control node number
- t represents the continuous time
- the series inverted pendulum system works in the repetition time period of t ⁇ [0,T]
- x k (p,t) ⁇ R n , u k (p,t) ⁇ R m and y k (p,t) ⁇ R l represent the state, input and output signal of the pth node of the series inverted pendulum system, respectively
- v k (p,t) ⁇ R i and w k (p,t) ⁇ R j represent the external bounded disturbance signal at the state end and the external bounded disturbance signal at the output end of the p-th node of the series inverted pendulum system, respectively, and the disturbance signal is derivable
- m represents the mass of the pendulum rod
- l represents the distance from the center of mass of the pendulum rod to the axis of rotation
- Step 2 Convert the state space equation of the original series inverted pendulum
- the third step design a robust iterative learning control algorithm according to the repetitive process theory
- the equivalent system output tracking error is defined as
- Y r (t) is the super vector of the desired output signal, and is the continuously derivable desired output trajectory
- U k (t) is the input value of the current cycle
- U k-1 (t) is the input value of the previous cycle
- ⁇ U k (t) is the correction value for the periodic update of the control system.
- Equation (20) The iterative learning update law in equation (20) is defined as the following form:
- I represents the identity matrix
- Equation (26) is transformed into a continuous discrete repetitive process model of the following form:
- ⁇ represents the operating frequency of the system
- the fourth step analyze the convergence of the robust iterative learning control algorithm in the limited frequency range
- the control goal of this application is to design a robust iterative learning control law to make the equivalent system (19) with external bounded disturbances robust and stable in a limited frequency range; first of all, it should be ensured that the equivalent system (19) has no external bounded disturbances. 19) stability;
- Condition 1 The matrix of the repetitive process model (26) All eigenvalues of have strictly negative real parts;
- Condition 3 The matrix of the transfer function of the repetitive process model (26) The modulus of its eigenvalue is strictly less than 1;
- the continuous discrete repetitive process model is said to have robust performance, and ⁇ is its performance index, and the smaller the value of ⁇ , the better the performance of the continuous discrete repetitive process model in suppressing interference;
- the content of the generalized bounded real lemma is:
- N 11 , N 12 , N 21 , and N 22 need to have different forms in different frequency ranges.
- N 11 -Q can be obtained And because - ⁇ 2 I ⁇ 0, so
- the continuous discrete repetitive process system (28) is guaranteed to have robust performance ⁇ ;
- the equivalent system (19) is robust and stable in the low and medium frequency range and has a robust performance ⁇ , and the output tracking error converges along the time and period directions;
- the low and medium frequency bands are -Q, and the high frequency bands are Q. Different frequency bands have different values.
- N 11 Q>0
- the corresponding conclusion formula (40) cannot guarantee its negative definiteness, so the scalar ⁇ >0 is introduced, and the following matrix is taken
- T 1 N 11 - ⁇ W 1 - ⁇ W 1 T
- T 2 N 11 - ⁇ W 2 - ⁇ W 2 T
- the equivalent system (19) is in the high frequency range Robust and stable with robust performance ⁇ , while output tracking error converges along time and period directions;
- the fifth step solve the control law gain of the robust iterative learning control algorithm
- equation (31) the left and right sides of the inequality are multiplied by diag ⁇ S 1 T ,S 1 T ,I,I ⁇ , diag ⁇ S 1 ,S 1 ,I,I ⁇ , where The following inequalities are obtained:
- the equivalent system (19) is robust and stable in the low and medium frequency range and has a robust performance ⁇ , and the output tracking error converges along the time and period directions, and the iterative learning control law
- the gain is given by give;
- the equivalent system (19) is robust and stable in the high frequency range and has a robust performance ⁇ , while the output tracking error converges along the time and period directions, and the gain of the iterative learning control law is Depend on given.
- the present application discloses a limited frequency range robust iterative learning control method for series inverted pendulums.
- the repetitive process theory and generalized bounded real lemma sufficient conditions to ensure the system stability and robust control performance are given, and the output is guaranteed.
- the convergence of the tracking error in the time domain and the frequency domain, and at the same time convert the condition into the corresponding linear matrix inequality to solve the robust iterative learning control law, this application not only considers the system characteristics of the time and operating dimensions of a single inverted pendulum subsystem , and can be directly applied to a series inverted pendulum system composed of multiple inverted pendulum subsystems, with good control accuracy, and has good application value for the verification of control theory and the study of systems with similar structures.
- the method has a simple structure and is easy to implement in engineering.
- FIG. 1 is a flowchart of an iterative learning control method for a series inverted pendulum provided by the present application.
- FIG. 2 is an overall structural diagram of a series inverted pendulum provided by the present application.
- FIG. 3 is a force analysis diagram of the trolley provided by the present application.
- FIG. 4 is a force analysis diagram of a pendulum rod provided by the present application.
- FIG. 5 is an output reference trace of a series inverted pendulum system provided by an embodiment of the present application.
- FIG. 6 is an output reference trace spectrum of a series inverted pendulum system provided by an embodiment of the present application.
- FIG. 7 is an output change surface of the third subsystem of the series inverted pendulum provided by an embodiment of the present application.
- FIG. 8 is an input change surface of the third subsystem of the series inverted pendulum provided by an embodiment of the present application.
- FIG. 9 is an error change surface of the third subsystem of the series inverted pendulum provided by an embodiment of the present application.
- FIG. 10 is a variation effect of root mean square error of a series inverted pendulum system provided by an embodiment of the present application.
- the present application discloses a limited frequency range robust iterative learning control method for a series inverted pendulum.
- the flow chart of the method is shown in Figure 1.
- the series inverted pendulum itself has the characteristics of strong coupling, nonlinearity and instability. Spatial models have certain difficulties. However, by making reasonable assumptions about the system and making a reasonable approximation of some system variables, the state space model of the series inverted pendulum system can be established in the inertial coordinate system using classical Newtonian mechanics.
- the method further includes:
- the pendulum is a strict rigid body and will not deform during movement.
- the series inverted pendulum system includes a plurality of first-order inverted pendulums connected in series by springs. According to Newtonian mechanics, the dynamic analysis of the first-order inverted pendulum at the p-th node is carried out separately, and the first-order inverted pendulum at the p-th node is divided by the isolation method. For the two parts of the trolley and the pendulum, the force analysis of the two parts is carried out respectively.
- the physical parameters of the series inverted pendulum are shown in Table 2.
- each parameter matrix of the system is
- each node of each subsystem is defined to have the same reference trajectory.
- the reference trajectory of each node’s pendulum swing angle is defined as:
- the reference trajectory angle of the inverted pendulum is set in the STM32F103C8T6 microcontroller.
- the above iterative learning controller algorithm is implemented by a STM32F103C8T6 chip.
- the overall system consists of STM32F103C8T6 microcontroller, MG513 encoder, DC motor, inverted pendulum mechanism and WDD35D4 angle sensor. Using the WDD35D4 angle sensor as the swing angle of the pendulum
Landscapes
- Engineering & Computer Science (AREA)
- Health & Medical Sciences (AREA)
- Artificial Intelligence (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Evolutionary Computation (AREA)
- Medical Informatics (AREA)
- Software Systems (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Feedback Control In General (AREA)
Abstract
一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法,涉及迭代学习控制领域,方法包括:建立串联倒立摆的状态空间方程;对原串联倒立摆的状态空间方程进行转换;根据重复过程理论设计鲁棒迭代学习控制算法;分析有限频率范围内的鲁棒迭代学习控制算法的收敛性;求解鲁棒迭代学习控制算法的控制律增益。所提算法将保证系统频域稳定并且具有鲁棒控制性能,同时在外界干扰存在时确保输出误差在时域和频域范围内的收敛性。
Description
本发明涉及迭代学习控制领域,尤其是一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法。
串联倒立摆是一个高阶次、强耦合、多变量的不稳定复杂系统,可以直观地反应非线性、稳定性和鲁棒性等控制问题,是对控制理论进行检验的一个良好装置。串联倒立摆是由若干个结构相同的倒立摆子系统串联而成,其中倒立摆子系统具有重要的工程应用背景。单级倒立摆的稳定控制在火箭飞行过程中的姿态控制中具有广泛应用。同时倒立摆与双足机器人的行走有相似性。日常生活中重心在上、支点在下的问题都与倒立摆有极大的相似性,故其稳定控制在实际中有广泛的应用,如海上钻井平台的稳定控制、卫星发射架的稳定控制、火箭姿态控制、飞机安全着陆、化工过程控制等。因此,由若干个倒立摆子系统组合而成的串联倒立摆具有很好的工程应用背景。
目前针对串联倒立摆的控制方法主要有:专家控制,模糊控制和神经网络控制等。专家控制的主体由知识库和推理机构组成,涉及到知识库的自动更新与规则自动生成,因此专家控制在实时性和信息的并行处理方面有很大的局限性。模糊控制具有较强的鲁棒性能和容错性能,但是由于其模糊的特性会导致系统的控制精度和动态品质的降低。神经网络控制具有较强的自适应能力,但是其必须要有已知的具体工程应用数据样本,同时还需要足够长的时间来进行在线或离线学习训练,因此其收敛速度缓慢。上述控制方法在系统的实时性和精确性上均存在较大局限,难以解决串联倒立摆的轨迹跟踪问题。
发明内容
本发明人针对上述问题及技术需求,提出了一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法。基于提升技术将重复运行的多维串联倒立摆系统转换为等效系统,然后为了进一步表示有界扰动与系统输出误差之间的联系,设计鲁棒迭代学习控制律将被控系统转换为一类连续离散重复过程模型。基于重 复过程理论,通过线性矩阵不等式表示鲁棒迭代学习控制算法。所提算法将保证系统频域稳定并且具有鲁棒控制性能,同时在外界干扰存在时确保输出误差在时域和频域范围内的收敛性。
本发明的技术方案如下:
一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法,包括如下步骤:
第一步:建立串联倒立摆的状态空间方程;

其中,


式(17)中k表示迭代周期,p表示控制节点序号,t代表连续时间,串联倒 立摆系统工作于t∈[0,T]的重复时间周期内;x
k(p,t)∈R
n,u
k(p,t)∈R
m和y
k(p,t)∈R
l分别表示串联倒立摆系统第p个节点的状态、输入和输出信号;v
k(p,t)∈R
i和w
k(p,t)∈R
j分别表示串联倒立摆系统第p个节点的状态端外部有界扰动和输出端外部有界扰动信号,并且扰动信号可导;

 和
 分别表示适当维数的系统矩阵;m表示摆杆质量,l表示摆杆质心到转动轴心的距离,J表示摆杆的转动惯量,M表示小车质量,a表示弹簧劲度系数,b表示小车摩擦系数;串联倒立摆系统第p个节点的状态会受到前后节点状态的影响,其中0≤p≤α-1,α表示串联倒立摆系统的总节点数,为已知的任意正整数;不失一般性,假设串联倒立摆系统满足边界条件x
k(p,0)=0,并且x
k(-1,t)=0,x
k(α,t)=0;
第二步:对原串联倒立摆的状态空间方程进行转换;
对于原串联倒立摆的状态空间方程(17),利用提升技术,定义关于输入、输出、状态和扰动信号的超级矢量U
k(t),Y
k(t),X
k(t),V
k(t),W
k(t)为如下形式:

则原串联倒立摆的状态空间方程(17)转换成等效系统:

其中,


第三步:根据重复过程理论设计鲁棒迭代学习控制算法;
定义等效系统输出跟踪误差为
e
k(t)=Y
r(t)-Y
k(t)
其中Y
r(t)为期望输出信号的超级矢量,且为连续可导的期望输出轨迹;
针对等效系统(19)设计如下形式的迭代学习控制律
U
k(t)=U
k-1(t)+ΔU
k(t) (20)
在式(20)中,U
k(t)是当前周期的输入量;U
k-1(t)是前一个周期的输入量;ΔU
k(t)是控制系统周期更新的修正量,为了便于分析,定义中间变量η
k(t),θ
k(t)和ζ
k(t)为

根据式(19)、式(20)和式(21)得到:


将式(20)中的迭代学习更新律定义为如下形式:

其中,

其中
 分别对应将迭代学习更新律与等效系统(19)结合,得到被控系统的重复过程模型为如下形式:

其中,

I表示单位矩阵;
重复过程模型(26)从系统误差e
k-1(t)到系统误差e
k(t)之间的传递函数为:

为了进一步表示系统外部有界扰动与系统输出之间的关系,将式(26)转换成如下形式的连续离散重复过程模型:

其中,

则连续离散重复过程模型(28)从系统外部有界扰动
 到系统误差e
k-1(t)之间的传递函数为:

ω表示系统工作频率;
第四步:分析有限频率范围内的鲁棒迭代学习控制算法的收敛性;
本申请的控制目标是设计鲁棒迭代学习控制律使得具有外部有界扰动的等效系统(19)在有限频率范围内鲁棒稳定;首先应保证在无外部有界扰动情况下等效系统(19)的稳定性;
在无外部有界扰动情况下,重复过程稳定和误差收敛需要满足三个条件:
条件一:重复过程模型(26)的矩阵
 的所有特征值都具有严格的负实部;
条件二:重复过程模型(26)的矩阵
 的谱半径严格小于1;
条件三:重复过程模型(26)传递函数的矩阵
 其特征值的模严格小于1;
在无外部有界扰动情况下,重复过程模型(26)在有限频率范围内稳定和误差收敛的结论为:
对于重复过程模型(26),若存在对称正定矩阵Q>0,P>0,Z>0和W
1>0使得如下线性矩阵不等式成立:


则无扰动的等效系统(19)在迭代学习更新律(24)的作用下,输出跟踪误差在低、中频段范围内沿时间和批次方向单调收敛;
对于重复过程模型(26),若存在对称正定矩阵Q>0,P>0,Z>0和W
1>0,以及标量τ>0使得如下线性矩阵不等式成立:


则无扰动的等效系统(19)在迭代学习更新律(24)作用下,输出跟踪误差在高频段范围内沿时间和批次方向单调收敛;
在无扰动结论的基础上进一步扩展带有外部有界扰动的等效系统(19)在有限频率范围内鲁棒稳定且具有鲁棒性能的结论;
若连续离散重复过程模型(28)从外部有界扰动到系统输出误差之间的传递 函数G
wz(s)满足
||G
wz(s)||
∞<γ (34)
则称连续离散重复过程模型具有鲁棒性能,γ为其性能指标,且γ取值越小,表明连续离散重复过程模型的抑制干扰的性能越好;
广义有界实引理内容为:
给定标量γ>0,对于给定系统的传递函数G(s)及其频率响应G(jω)=C(jωI-A)
-1B,以下不等式等价:
(i)频率响应不等式

(ii)线性矩阵不等式

其中Q>0,P=P
T>0,
 系统的频率范围以及不同频率范围内Ψ取值如表1所示
表1系统的频率范围

注释:设
 则

N
11、N
12、N
21、N
22需要在不同频率范围内具备不同的形式。
将连续离散重复过程模型(28)的系数矩阵(29)代入广义有界实引理的线性矩阵不等式,同时令

 并取频率响应不等式中的矩阵
 则线性矩阵不等式写成:

且式(35)又可以写成:

其中
 对于式(36)中的Λ
⊥,取

其次,取矩阵

则得到下列等式:

其中定义Q>0,根据广义有界实引理中N
11=-Q可得
 又因为-γ
2I<0所以

根据投影引理
 得到以下不等式成立:

其中
 对式(38)使用Schur补引理得到:

根据广义有界实引理G(jω)
*G(jω)<γ
2,得到ρ(G(jω))<γ,由于 ρ(G(jω))≤||G(jω)||
∞,则得到:
||G(jω)||
∞<γ
保证了连续离散重复过程系统(28)具有鲁棒性能γ;
因此对于低、中频段得到下列结论:
针对式(26)的重复过程模型,给定对称矩阵P>0,Q>0,Z>0,W
1>0和W
2>0以及给定标量γ>0使得式(30)和式(31)以及下列矩阵不等式成立:

则在迭代学习更新律(24)作用下,等效系统(19)在低、中频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛;
根据广义有界实引理中N矩阵N
11元素在低、中频范围内和高频范围内的取值可知,低中频段为-Q,高频段为Q,不同频段取值不同,当系统工作于高频段时N
11=Q>0,相应的结论式(40)无法保证其负定,因此引入标量τ>0,取下列矩阵

则得到:

则相应高频段的结论为:
针对式(26)的重复过程模型,给定对称矩阵P>0,Q>0,Z>0,W
1>0和W
2>0以及给定标量τ>0和γ>0使得式(32)和式(33)以及下列矩阵不等式成立:

其中T
1=N
11-τW
1-τW
1
T,T
2=N
11-τW
2-τW
2
T;则在迭代学习更新律(24)作用下,等效系统(19)在高频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛;
第五步:求解鲁棒迭代学习控制算法的控制律增益;
上述结论不能直接用于控制律的求解,需要进行一定的转换才能进行求解。
根据式(30)得出式(42)

取
 取
 因此Σ=[-ρ
2I ρ
1I],定义ρ
2<0,ρ
1>0,则得到:

运用投射引理得到如下结果:

将重复过程模型的系数矩阵(27)代入式(44)并在上式不等式左右两边乘以diag{S
1
T,S
1
T}、diag{S
1,S
1},其中
 得到如下不等式:

其中

将重复过程模型的系数矩阵式(27)代入式(31),因此得到下列不等式:

在式(31)中,不等式左右两边乘以diag{S
1
T,S
1
T,I,I}、diag{S
1,S
1,I,I},其中
 得到下列不等式:

化简得到下列不等式:

其中

将重复过程模型的系数矩阵(27)代入式(40),得到:

其中,
Γ
1=N
22+A
ΤW
1+W
1
ΤA+K
1
TB
TW
1+W
1
TBK
1,Γ
2=-K
1
TB
TC
TW
2-A
TC
TW
2+W
1
TBK
2,Γ
3=N
22+W
2
T+W
2-K
2
ΤB
TC
TW
2-W
2
ΤCBK
2,
在式(49)左右两边乘以diag{S
1
T,S
2
T,S
1
T,S
2
T,I,I,I}、diag{S
1,S
2,S
1,S
2,I,I,I},其中
 得到

其中,


令X
1=K
1S
1,X
2=K
2S
2,
对于低、中频段得出下列结论:
针对式(26)的重复过程模型,给定适当维数矩阵X
1,X
2,对称矩阵

 S
1>0和S
2>0以及标量ρ
1>0,ρ
2<0和γ>0使得下列线性矩阵不等式成立:


则在迭代学习更新律(24)作用下,等效系统(19)在低、中频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛,迭代学习控制律的增益由
 给出;
同时相应高频段的结论为:
针对式(26)的重复过程模型,给定适当维数矩阵X
1,X
2,对称矩阵

 S
1>0和S
2>0以及标量ρ
1>0,ρ
2<0,γ>0和τ>0使得式(51)以及下列线性矩阵不等式成立:


其中
 则在迭代学习更新律(24)作用下,等效系统(19)在高频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛,迭代学习控制律的增益由
 给出。
本发明的有益技术效果是:
本申请公开了一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法,根据重复过程理论和广义有界实引理,给出确保系统稳定和具有鲁棒控制性能的充分条件并保证了输出跟踪误差在时域和频域内的收敛性,同时将该条件转换成相应的线性矩阵不等式对鲁棒迭代学习控制律进行求解,本申请不仅考虑了单个倒立摆子系统时间和运行维度的系统特性,而且能直接应用于由多个倒立摆子系统组成的串联倒立摆系统,具有较好的控制精度,对于控制理论的验证以及具有相似结构系统的研究具有良好的应用价值,同时,本申请的方法结构简单,易于工程实现。
图1是本申请提供的串联倒立摆的迭代学习控制方法的流程图。
图2是本申请提供的串联倒立摆整体结构图。
图3是本申请提供的小车受力分析图。
图4是本申请提供的摆杆受力分析图。
图5是本申请一实施例提供的串联倒立摆系统的输出参考轨迹。
图6是本申请一实施例提供的串联倒立摆系统的输出参考轨迹频谱。
图7是本申请一实施例提供的串联倒立摆第3个子系统的输出变化曲面。
图8是本申请一实施例提供的串联倒立摆第3个子系统的输入变化曲面。
图9是本申请一实施例提供的串联倒立摆第3个子系统的误差变化曲面。
图10是本申请一实施例提供的串联倒立摆系统的均方根误差变化效果。
下面结合附图对本发明的具体实施方式做进一步说明。
本申请公开了一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法,其方法流程图如图1所示,串联倒立摆本身具有强耦合、非线性以及不稳定等特点,对其建立状态空间模型具有一定的难度。但是通过对系统的合理假设,将部分系统变量进行合理的近似后,就可以使用经典的牛顿力学在惯性坐标系内对串联倒立摆系统建立的状态空间模型。
在建立串联倒立摆的状态空间方程的步骤之前,方法还包括:
对串联倒立摆进行建模之前,对串联倒立摆系统作如下假设:
(1)摆体是严格的刚体,运动过程中不会变形,
(2)小车与导轨间的摩擦力与相对速度成正比,忽略空气阻力及其他摩擦力,(3)外力对串联倒立摆系统的作用无时滞。
串联倒立摆系统包括多个通过弹簧串联的一级倒立摆,根据牛顿力学先对第p个节点的一级倒立摆单独进行动力学分析,利用隔离法将第p个节点的一级倒立摆分为小车和摆杆两个部分,对两个部分分别进行受力分析。串联倒立摆的物理量参数如表2所示。
表2串联倒立摆系统物理量参数表


结合图2-图4所示,对小车进行受力分析,在水平方向上,由牛顿力学分析得到小车的运动方程为:

由假设得到:

对摆杆进行受力分析,在水平方向上得到:

将式(3)求导展开得到:

同时根据串联倒立摆整体结构得到:

将式(5)、式(4)和式(2)代入式(1)得到:

将式(6)化简合并得到系统第一运动方程式(7)

对摆杆进行受力分析,根据力矩平衡方程得到:

在摆杆竖直方向上受力分析得到:

展开式(9)得到:

将式(4)和式(10)代入式(8)得到系统第二运动方程式(11)

为实现串联倒立摆在平衡点附近微小的角度内重复摆动,同时对串联倒立摆系统变量进行如下近似处理:

同时:

将周期变量k和时间变量t加入第一运动方程式(7)和第二运动方程式(11)中并根据式(12)和式(13)简化得到串联倒立摆的运动方程为:

由式(14)的第一个方程得到:

将式(15)代入式(14)的第二个方程得到:

将式(16)回代式(15)的第一个方程得到:

取
 同时设置如下形式状态变量:


u
k(p,t)=F
k(p,t)
并在系统每个倒立摆子系统节点中引入状态端外部有界扰动v
k(p,t)和输出端外部有界扰动信号w
k(p,t),则得到串联倒立摆的状态空间方程:

针对式(17)所描述的串联倒立摆,选取各项结构参数值分别为:
M=1(kg),m=0.2(kg),l=0.3(m),a=1(N/m),
b=0.3(N/m/sec),g=9.8(m/s
2),J=0.006(kg·m
2).
同时取串联倒立摆各子系统的状态初值x
k(p,0)=0,u
k(p,0)=0。根据式(17)系统各个参数矩阵为


设定串联倒立摆包含6个子系统节点,根据串联倒立摆系统的特点,定义每个子系统各个节点具有相同的参考轨迹,考虑分别定义每个节点摆杆摆动角度的参考轨迹为:

倒立摆的参考轨迹角度在STM32F103C8T6单片机内进行设定,参考轨迹在时域中的曲线如图5所示,绘制相应的频谱曲线如图6所示,由图6可知参考轨迹的有效谐波在0到10HZ之间全部衰减,因此可以直接选取该频段为系统运行的低频范围,即ω
l=4π=62.832,对应于系统运行的低频范围。同时,假设每个倒立摆子系统的状态端外界扰动为
v
k(p,t)=0.01sin(kt),p=1,2,…,6.
以及输出端外界扰动为
w
k(p,t)=0.01sin(kt),p=1,2,…,6.
给定系统的鲁棒性能指标γ=0.9,并求解式(51)、式(52)和式(53)的线性矩阵不等式可得迭代学习更新律(24)中的矩阵增益为


上述迭代学习控制器算法通过一块STM32F103C8T6芯片实现。整体系统由STM32F103C8T6单片机、MG513编码器、直流电机、倒立摆机械机构和WDD35D4角传感器等几部分组成。利用WDD35D4角传感器作为摆杆摆动角度
Claims (2)
- 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法,其特征在于,所述方法包括如下步骤:第一步:建立串联倒立摆的状态空间方程;
 其中,


 式(17)中k表示迭代周期,p表示控制节点序号,t代表连续时间,串联倒立摆系统工作于t∈[0,T]的重复时间周期内;x k(p,t)∈R n,u k(p,t)∈R m和 y k(p,t)∈R l分别表示串联倒立摆系统第p个节点的状态、输入和输出信号;v k(p,t)∈R i和w k(p,t)∈R j分别表示串联倒立摆系统第p个节点的状态端外部有界扰动和输出端外部有界扰动信号,并且扰动信号可导;
 和
 分别表示适当维数的系统矩阵;m表示摆杆质量,l表示摆杆质心到转动轴心的距离,J表示摆杆的转动惯量,M表示小车质量,a表示弹簧劲度系数,b表示小车摩擦系数;串联倒立摆系统第p个节点的状态会受到前后节点状态的影响,其中0≤p≤α-1,α表示串联倒立摆系统的总节点数,为已知的任意正整数;假设串联倒立摆系统满足边界条件x k(p,0)=0,并且x k(-1,t)=0,x k(α,t)=0;
 第二步:对原串联倒立摆的状态空间方程进行转换;对于所述原串联倒立摆的状态空间方程(17),利用提升技术,定义关于输入、输出、状态和扰动信号的超级矢量U k(t),Y k(t),X k(t),V k(t),W k(t)为如下形式:
 则所述原串联倒立摆的状态空间方程(17)转换成等效系统:
 其中,

 第三步:根据重复过程理论设计鲁棒迭代学习控制算法;定义所述等效系统输出跟踪误差为e k(t)=Y r(t)-Y k(t)其中Y r(t)为期望输出信号的超级矢量,且为连续可导的期望输出轨迹;针对所述等效系统(19)设计如下形式的迭代学习控制律U k(t)=U k-1(t)+ΔU k(t) (20)在式(20)中,U k(t)是当前周期的输入量;U k-1(t)是前一个周期的输入量;ΔU k(t)是控制系统周期更新的修正量,为了便于分析,定义中间变量η k(t),和ζ k(t)为

 根据式(19)、式(20)和式(21)得到:

 将式(20)中的迭代学习更新律定义为如下形式:
 其中,
 其中分别对应将所述迭代学习更新律与所述等效系统(19)结合, 得到被控系统的重复过程模型为如下形式:

 其中,
 I表示单位矩阵;所述重复过程模型(26)从系统误差e k-1(t)到系统误差e k(t)之间的传递函数为:
 为了进一步表示系统外部有界扰动与系统输出之间的关系,将式(26)转换成如下形式的连续离散重复过程模型:
 其中,
 则所述连续离散重复过程模型(28)从系统外部有界扰动到系统误差e k-1(t)之间的传递函数为:

 ω表示系统工作频率;第四步:分析有限频率范围内的所述鲁棒迭代学习控制算法的收敛性;本申请的控制目标是设计鲁棒迭代学习控制律使得具有外部有界扰动的所述等效系统(19)在有限频率范围内鲁棒稳定;首先应保证在无外部有界扰动情况下所述等效系统(19)的稳定性;在无外部有界扰动情况下,重复过程稳定和误差收敛需要满足三个条件:条件一:所述重复过程模型(26)的矩阵的所有特征值都具有严格的负实部;条件二:所述重复过程模型(26)的矩阵
 的谱半径严格小于1; 条件三:所述重复过程模型(26)传递函数的矩阵

 其特征值的模严格小于1;
 在无外部有界扰动情况下,所述重复过程模型(26)在有限频率范围内稳定和误差收敛的结论为:对于所述重复过程模型(26),若存在对称正定矩阵Q>0,P>0,Z>0和W 1>0使得如下线性矩阵不等式成立:

 则无扰动的等效系统(19)在所述迭代学习更新律(24)的作用下,输出跟踪误差在低、中频段范围内沿时间和批次方向单调收敛;对于重复过程模型(26),若存在对称正定矩阵Q>0,P>0,Z>0和W 1>0,以及标量τ>0使得如下线性矩阵不等式成立:

 则无扰动的等效系统(19)在所述迭代学习更新律(24)作用下,输出跟踪误差在高频段范围内沿时间和批次方向单调收敛;在无扰动结论的基础上进一步扩展带有外部有界扰动的等效系统(19)在有限频率范围内鲁棒稳定且具有鲁棒性能的结论;若所述连续离散重复过程模型(28)从外部有界扰动到系统输出误差之间的传递函数G wz(s)满足||G wz(s)|| ∞<γ (34)则称所述连续离散重复过程模型具有鲁棒性能,γ为其性能指标,且γ取值越小,表明所述连续离散重复过程模型的抑制干扰的性能越好;将所述连续离散重复过程模型(28)的系数矩阵(29)代入广义有界实引理的线性矩阵不等式,同时令
 并取频率响应不等式中的矩阵
 则线性矩阵不等式写成:

 且式(35)又可以写成:
 其中对于式(36)中的Λ ⊥,取

 其次,取矩阵
 则得到下列等式:
 其中定义Q>0,根据广义有界实引理中N 11=-Q可得又因为-γ 2I<0所以

 根据投影引理得到以下不等式成立:

 其中对式(38)使用Schur补引理得到:

 根据广义有界实引理G(jω) *G(jω)<γ 2,得到ρ(G(jω))<γ,由于ρ(G(jω))≤||G(jω)|| ∞,则得到:||G(jω)|| ∞<γ保证了所述连续离散重复过程系统(28)具有鲁棒性能γ;因此对于低、中频段得到下列结论:针对式(26)所述的重复过程模型,给定对称矩阵P>0,Q>0,Z>0,W 1>0和W 2>0以及给定标量γ>0使得式(30)和式(31)以及下列矩阵不等式成立:
 则在所述迭代学习更新律(24)作用下,所述等效系统(19)在低、中频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛;根据广义有界实引理中N矩阵N 11元素在低、中频范围内和高频范围内的取值可知,低中频段为-Q,高频段为Q,不同频段取值不同,当系统工作于高频段时N 11=Q>0,相应的结论式(40)无法保证其负定,因此引入标量τ>0,取下列矩阵
 则得到:
 则相应高频段的结论为:针对式(26)所述的重复过程模型,给定对称矩阵P>0,Q>0,Z>0,W 1>0和W 2>0以及给定标量τ>0和γ>0使得式(32)和式(33)以及下列矩阵不等式成立:
 其中T 1=N 11-τW 1-τW 1 T,T 2=N 11-τW 2-τW 2 T;则在所述迭代学习更新律(24)作用下,所述等效系统(19)在高频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛;第五步:求解所述鲁棒迭代学习控制算法的控制律增益;根据式(30)得出式(42)
 取取
 因此Σ=[-ρ 2I ρ 1I],定义ρ 2<0,ρ 1>0,则得到:

 运用投射引理得到如下结果:
 将所述重复过程模型的系数矩阵(27)代入式(44)并在上式不等式左右两边乘以diag{S 1 T,S 1 T}、diag{S 1,S 1},其中S 1=W 1 -1,得到如下不等式:
 其中
 将所述重复过程模型的系数矩阵式(27)代入式(31),因此得到下列不等式:
 在式(31)中,不等式左右两边乘以diag{S 1 T,S 1 T,I,I}、diag{S 1,S 1,I,I},其中S 1=W 1 -1,得到下列不等式:
 化简得到下列不等式:
 其中
 将所述重复过程模型的系数矩阵(27)代入式(40),得到:
 其中,Γ 1=N 22+A ΤW 1+W 1 ΤA+K 1 TB TW 1+W 1 TBK 1,Γ 2=-K 1 TB TC TW 2-A TC TW 2+W 1 TBK 2,Γ 3=N 22+W 2 T+W 2-K 2 ΤB TC TW 2-W 2 ΤCBK 2,在式(49)左右两边乘以diag{S 1 T,S 2 T,S 1 T,S 2 T,I,I,I}、diag{S 1,S 2,S 1,S 2,I,I,I},其中S 1=W 1 -1,S 2=W 2 -1得到
 其中,
 令X 1=K 1S 1,X 2=K 2S 2,对于低、中频段得出下列结论:针对式(26)所述的重复过程模型,给定适当维数矩阵X 1,X 2,对称矩阵S 1>0和S 2>0以及标量ρ 1>0,ρ 2<0和γ>0使得下列线性矩阵不等式成立:

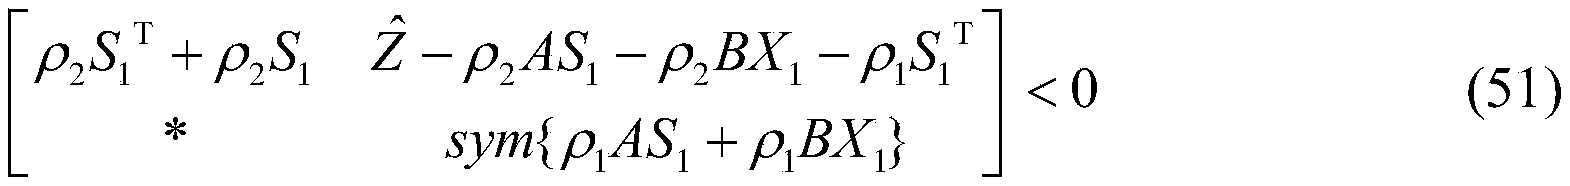

 则在所述迭代学习更新律(24)作用下,所述等效系统(19)在低、中频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛,所述迭代学习控制律的增益由给出;
 同时相应高频段的结论为:针对式(26)所述的重复过程模型,给定适当维数矩阵X 1,X 2,对称矩阵S 1>0和S 2>0以及标量ρ 1>0,ρ 2<0,γ>0和τ>0使得式(51)以及下列线性矩阵不等式成立:


 其中则在所述迭代学习更新律(24)作用下,所述等效系统(19)在高频率范围内鲁棒稳定且具有鲁棒性能γ,同时输出跟踪误差沿时间和周期方向收敛,所述迭代学习控制律的增益由
 K 2=X 2S 2 -1给出。

- 根据权利要求1所述的串联倒立摆的有限频率范围鲁棒迭代学习控制方法,其特征在于,在所述建立串联倒立摆的状态空间方程的步骤之前,所述方法还包括:对串联倒立摆进行建模之前,对所述串联倒立摆系统作如下假设:(1)摆体是严格的刚体,运动过程中不会变形,(2)小车与导轨间的摩擦力与相对速度成正比,忽略空气阻力及其他摩擦力,(3)外力对所述串联倒立摆系统的作用无时滞;所述串联倒立摆系统包括多个通过弹簧串联的一级倒立摆,根据牛顿力学先对第p个节点的一级倒立摆单独进行动力学分析,利用隔离法将第p个节点的一级倒立摆分为小车和摆杆两个部分,对所述两个部分分别进行受力分析;对所述小车进行受力分析,在水平方向上,由牛顿力学分析得到小车的运动方程为:
 在式(1)中,L p表示第p个节点小车相对初始位置的位移,F表示作用于串联倒 立摆系统上的控制力,F p-1表示第p-1个节点对第p个节点的作用力,F p+1表示第p+1个节点对第p个节点的作用力,F N表示摆杆与小车水平方向的相互作用力,F f表示小车与导轨间的摩擦力;由假设得到:
 对摆杆进行受力分析,在水平方向上得到:
 在式(3)中,θ p表示第p个节点摆杆与竖直向上方向的夹角;将式(3)求导展开得到:
 同时根据串联倒立摆整体结构得到:
 将式(5)、式(4)和式(2)代入式(1)得到:
 将式(6)化简合并得到系统第一运动方程式(7)
 对所述摆杆进行受力分析,根据力矩平衡方程得到:
 在式(8)中,F T表示摆杆与小车竖直方向的相互作用力;在摆杆竖直方向上受力分析得到:
 在式(9)中,G m表示摆杆的重力;展开式(9)得到:
 将式(4)和式(10)代入式(8)得到系统第二运动方程式(11)
 为实现串联倒立摆在平衡点附近微小的角度内重复摆动,同时对所述串联倒立摆系统变量进行如下近似处理:
 同时:
 将周期变量k和时间变量t加入所述第一运动方程式(7)和所述第二运动方程式(11)中并根据式(12)和式(13)简化得到串联倒立摆的运动方程为:
 由式(14)的第一个方程得到:
 将式(15)代入式(14)的第二个方程得到:
 将式(16)回代式(15)的第一个方程得到:取
 同时设置如下形式状态变量:


 u k(p,t)=F k(p,t)并在系统每个倒立摆子系统节点中引入状态端外部有界扰动v k(p,t)和输出端外部有界扰动信号w k(p,t),则得到所述串联倒立摆的状态空间方程。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010674050.3 | 2020-07-14 | ||
| CN202010674050.3A CN111580392B (zh) | 2020-07-14 | 2020-07-14 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022012155A1 true WO2022012155A1 (zh) | 2022-01-20 |
Family
ID=72124031
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2021/094741 Ceased WO2022012155A1 (zh) | 2020-07-14 | 2021-05-20 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
Country Status (2)
| Country | Link |
|---|---|
| CN (1) | CN111580392B (zh) |
| WO (1) | WO2022012155A1 (zh) |
Cited By (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114527664A (zh) * | 2022-02-28 | 2022-05-24 | 北京航空航天大学 | 一种具有非对称时滞的动态不确定性系统的自适应跟踪控制方法 |
| CN114559437A (zh) * | 2022-03-25 | 2022-05-31 | 合肥工业大学 | 机械手臂系统在有限频域扰动下的稳定鲁棒控制方法 |
| CN114625011A (zh) * | 2022-03-23 | 2022-06-14 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN114944796A (zh) * | 2022-05-20 | 2022-08-26 | 上海航天控制技术研究所 | 基于参数补偿的同轴串联系统驱动力同步协调控制方法 |
| CN115016286A (zh) * | 2022-07-01 | 2022-09-06 | 天津大学 | 非线性工业系统数据驱动强化学习鲁棒控制方法 |
| CN115903480A (zh) * | 2022-11-02 | 2023-04-04 | 山东交通学院 | 一种有限时间鲁棒镇定控制方法 |
| CN115903802A (zh) * | 2022-11-14 | 2023-04-04 | 福州大学 | 基于非线性变参数无人船模型的h∞艏向控制方法 |
| CN116931592A (zh) * | 2023-08-25 | 2023-10-24 | 湖南大学 | 一种悬挂运输工具的无人机系统的鲁棒控制方法 |
| CN117250863A (zh) * | 2023-09-26 | 2023-12-19 | 天津大学 | 一种基于特征值计算的单输入单输出负虚系统判别方法 |
| CN117850237A (zh) * | 2024-01-10 | 2024-04-09 | 西安工程大学 | 基于迭代学习控制的跟踪处理方法、装置、设备和介质 |
| CN117951650A (zh) * | 2024-03-27 | 2024-04-30 | 湖南大学 | 融合奇异谱分析与鲁棒子空间辨识的动态称量方法及系统 |
| CN117991629A (zh) * | 2023-10-27 | 2024-05-07 | 无锡学院 | 一种搅拌釜反应器的非线性间歇过程的鲁棒控制方法 |
| CN118170035A (zh) * | 2024-05-16 | 2024-06-11 | 南昌大学 | 基于深度学习的自平衡机器人设计方法及系统 |
| CN119292062A (zh) * | 2024-10-09 | 2025-01-10 | 东南大学 | 海上钢架平台模型的鲁棒可靠h∞控制方法 |
| CN120634883A (zh) * | 2025-08-13 | 2025-09-12 | 中国科学院长春光学精密机械与物理研究所 | 一种基于滑模变结构控制的图像融合模型鲁棒性增强方法 |
| CN120909144A (zh) * | 2025-10-11 | 2025-11-07 | 南京信息工程大学 | 基于参数不确定倒立摆系统的区间二型模糊滑模控制方法 |
Families Citing this family (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111580392B (zh) * | 2020-07-14 | 2021-06-15 | 江南大学 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
| CN112327971B (zh) * | 2020-10-27 | 2021-06-15 | 江南大学 | 金属棒温度分布系统的鲁棒启发式迭代学习控制方法 |
| CN112486191B (zh) * | 2020-10-28 | 2022-07-01 | 杭州电子科技大学 | 一种基于增强型误差模型的平衡车控制方法 |
| CN112230549B (zh) * | 2020-10-28 | 2022-06-03 | 杭州电子科技大学 | 一种基于鲁棒自适应控制器的平衡车控制方法 |
| CN115781658B (zh) * | 2021-09-10 | 2024-12-06 | 腾讯科技(深圳)有限公司 | 构建机器人的控制器的方法和机器人 |
| CN114721268B (zh) * | 2022-04-08 | 2022-11-04 | 江南大学 | 注塑成型喷嘴压力鲁棒启发式迭代学习控制方法 |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2008067404A2 (en) * | 2006-11-29 | 2008-06-05 | Honda Motor Co., Ltd. | Determination of foot placement for humanoid push recovery |
| CN110134011A (zh) * | 2019-04-23 | 2019-08-16 | 浙江工业大学 | 一种倒立摆自适应迭代学习反演控制方法 |
| US20190272752A1 (en) * | 2018-03-05 | 2019-09-05 | NEC Laboratories Europe GmbH | Method for robust control of a machine learning system and robust control system |
| CN110908280A (zh) * | 2019-10-30 | 2020-03-24 | 宁波大学 | 一种小车-二级倒立摆系统优化控制方法 |
| CN111360811A (zh) * | 2018-12-26 | 2020-07-03 | 中国科学院沈阳自动化研究所 | 一种基于串联机器人的倒立摆教学系统及控制方法 |
| CN111580392A (zh) * | 2020-07-14 | 2020-08-25 | 江南大学 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
Family Cites Families (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN101673354A (zh) * | 2009-06-12 | 2010-03-17 | 北京工业大学 | 操作条件反射自动机及其在仿生自主学习控制中的应用 |
| CN101846979A (zh) * | 2010-06-29 | 2010-09-29 | 北京航空航天大学 | 一种精确目标跟踪的超前迭代学习控制方法 |
| CN104570740A (zh) * | 2015-01-21 | 2015-04-29 | 江南大学 | 一种输入饱和机械臂系统的周期自适应学习控制方法 |
| CN107561929B (zh) * | 2017-07-25 | 2020-01-14 | 北京理工大学 | 一种伺服系统的无模型鲁棒自适应优化方法 |
| US11568236B2 (en) * | 2018-01-25 | 2023-01-31 | The Research Foundation For The State University Of New York | Framework and methods of diverse exploration for fast and safe policy improvement |
| CN109375512B (zh) * | 2018-11-20 | 2021-04-09 | 中南大学 | 基于rbf-arx模型的保证倒立摆系统闭环稳定的预测控制方法 |
| CN109709802B (zh) * | 2018-12-14 | 2020-06-16 | 江南大学 | 基于迭代学习控制的有源电子梯形电路的控制方法 |
| CN110221539B (zh) * | 2019-05-17 | 2022-04-08 | 江苏理工学院 | 基于线性扩张观测器的四旋翼非奇异终端滑模控制方法 |
| CN111736471B (zh) * | 2020-07-14 | 2021-06-15 | 江南大学 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
-
2020
- 2020-07-14 CN CN202010674050.3A patent/CN111580392B/zh active Active
-
2021
- 2021-05-20 WO PCT/CN2021/094741 patent/WO2022012155A1/zh not_active Ceased
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2008067404A2 (en) * | 2006-11-29 | 2008-06-05 | Honda Motor Co., Ltd. | Determination of foot placement for humanoid push recovery |
| US20190272752A1 (en) * | 2018-03-05 | 2019-09-05 | NEC Laboratories Europe GmbH | Method for robust control of a machine learning system and robust control system |
| CN111360811A (zh) * | 2018-12-26 | 2020-07-03 | 中国科学院沈阳自动化研究所 | 一种基于串联机器人的倒立摆教学系统及控制方法 |
| CN110134011A (zh) * | 2019-04-23 | 2019-08-16 | 浙江工业大学 | 一种倒立摆自适应迭代学习反演控制方法 |
| CN110908280A (zh) * | 2019-10-30 | 2020-03-24 | 宁波大学 | 一种小车-二级倒立摆系统优化控制方法 |
| CN111580392A (zh) * | 2020-07-14 | 2020-08-25 | 江南大学 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
Non-Patent Citations (3)
| Title |
|---|
| HONGFENG TAO, YAN LIU, HUIZHONG YANG: "Robust iterative learning fault-tolerant control for a dual-rate sampling system with actuator faults and output delay", NANJING LIGONG DAXUE XUEBAO - JOURNAL OF NANJING UNIVERSITY OFSCIENCE AND TECHNOLOGY, GAI-BAN BIANJIBU, NANJING, CN, vol. 42, no. 4, 1 August 2018 (2018-08-01), CN , pages 1 - 9, XP055887609, ISSN: 1005-9830, DOI: 0.14177 /j.cnki.32-1397n.2018.42.04.007 * |
| LI, ZHANMING, AI WEN-HUAN,CHEN RUO-ZHU: "Research on iterative learning control scheme for inverted pendulum", TRANSDUCER AND MICROSYSTEM TECHNOLOGIES, 20 April 2008 (2008-04-20), XP055887614, [retrieved on 20220204] * |
| XIANHE ZHANG ; JIE WU ; XISHENG ZHAN: "Iterative Learning Control Study on Single Inverted Pendulum", 2008 INTERNATIONAL SYMPOSIUM ON INTELLIGENT INFORMATION TECHNOLOGY APPLICATION WORKSHOPS : IITAW ; SHANGHAI, CHINA, 21 - 22 DECEMBER 2008, IEEE, PISCATAWAY, NJ, USA, 21 December 2008 (2008-12-21), Piscataway, NJ, USA , pages 155 - 158, XP031382756, ISBN: 978-0-7695-3505-0 * |
Cited By (21)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114527664A (zh) * | 2022-02-28 | 2022-05-24 | 北京航空航天大学 | 一种具有非对称时滞的动态不确定性系统的自适应跟踪控制方法 |
| CN114625011B (zh) * | 2022-03-23 | 2024-04-02 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN114625011A (zh) * | 2022-03-23 | 2022-06-14 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN114559437A (zh) * | 2022-03-25 | 2022-05-31 | 合肥工业大学 | 机械手臂系统在有限频域扰动下的稳定鲁棒控制方法 |
| CN114559437B (zh) * | 2022-03-25 | 2023-06-27 | 合肥工业大学 | 机械手臂系统在有限频域扰动下的稳定鲁棒控制方法 |
| CN114944796A (zh) * | 2022-05-20 | 2022-08-26 | 上海航天控制技术研究所 | 基于参数补偿的同轴串联系统驱动力同步协调控制方法 |
| CN114944796B (zh) * | 2022-05-20 | 2024-06-11 | 上海航天控制技术研究所 | 基于参数补偿的同轴串联系统驱动力同步协调控制方法 |
| CN115016286A (zh) * | 2022-07-01 | 2022-09-06 | 天津大学 | 非线性工业系统数据驱动强化学习鲁棒控制方法 |
| CN115903480A (zh) * | 2022-11-02 | 2023-04-04 | 山东交通学院 | 一种有限时间鲁棒镇定控制方法 |
| CN115903802A (zh) * | 2022-11-14 | 2023-04-04 | 福州大学 | 基于非线性变参数无人船模型的h∞艏向控制方法 |
| CN115903802B (zh) * | 2022-11-14 | 2025-07-04 | 福州大学 | 基于非线性变参数无人船模型的h∞艏向控制方法 |
| CN116931592A (zh) * | 2023-08-25 | 2023-10-24 | 湖南大学 | 一种悬挂运输工具的无人机系统的鲁棒控制方法 |
| CN117250863A (zh) * | 2023-09-26 | 2023-12-19 | 天津大学 | 一种基于特征值计算的单输入单输出负虚系统判别方法 |
| CN117250863B (zh) * | 2023-09-26 | 2024-03-08 | 天津大学 | 一种基于特征值计算的单输入单输出负虚系统判别方法 |
| CN117991629A (zh) * | 2023-10-27 | 2024-05-07 | 无锡学院 | 一种搅拌釜反应器的非线性间歇过程的鲁棒控制方法 |
| CN117850237A (zh) * | 2024-01-10 | 2024-04-09 | 西安工程大学 | 基于迭代学习控制的跟踪处理方法、装置、设备和介质 |
| CN117951650A (zh) * | 2024-03-27 | 2024-04-30 | 湖南大学 | 融合奇异谱分析与鲁棒子空间辨识的动态称量方法及系统 |
| CN118170035A (zh) * | 2024-05-16 | 2024-06-11 | 南昌大学 | 基于深度学习的自平衡机器人设计方法及系统 |
| CN119292062A (zh) * | 2024-10-09 | 2025-01-10 | 东南大学 | 海上钢架平台模型的鲁棒可靠h∞控制方法 |
| CN120634883A (zh) * | 2025-08-13 | 2025-09-12 | 中国科学院长春光学精密机械与物理研究所 | 一种基于滑模变结构控制的图像融合模型鲁棒性增强方法 |
| CN120909144A (zh) * | 2025-10-11 | 2025-11-07 | 南京信息工程大学 | 基于参数不确定倒立摆系统的区间二型模糊滑模控制方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| CN111580392B (zh) | 2021-06-15 |
| CN111580392A (zh) | 2020-08-25 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111580392B (zh) | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 | |
| CN111319036B (zh) | 基于自适应算法的移动机械臂位置/力自抗扰控制方法 | |
| CN113183154B (zh) | 一种柔性关节机械臂的自适应反演控制方法 | |
| CN106774273B (zh) | 针对变时滞控制系统执行器故障的滑模预测容错控制方法 | |
| CN107942670B (zh) | 一种双柔性空间机械臂模糊鲁棒滑模削抖运动控制方法 | |
| CN111596545A (zh) | 一种多输入多输出机械系统自适应容错预设性能控制方法 | |
| CN116068901B (zh) | 一种基于自适应有限时间扰动观测器的柔性连杆机械臂控制方法 | |
| CN105607472B (zh) | 非线性二元机翼的自适应反演滑模控制方法及装置 | |
| CN110134011A (zh) | 一种倒立摆自适应迭代学习反演控制方法 | |
| CN104950678A (zh) | 一种柔性机械臂系统的神经网络反演控制方法 | |
| CN115981149B (zh) | 基于安全强化学习的高超声速飞行器最优控制方法 | |
| CN108388114A (zh) | 一种基于输出重定义的柔性机械臂复合控制方法 | |
| CN110442020A (zh) | 一种新型的基于鲸鱼优化算法的容错控制方法 | |
| CN106773684B (zh) | 基于智能学习评价的柔性机械臂复合控制方法 | |
| Hu et al. | Proximal policy optimization with an integral compensator for quadrotor control | |
| CN115079574B (zh) | 一种挠性高超声速飞行器分布式故障补偿方法 | |
| Shen et al. | Attitude active disturbance rejection control of the quadrotor and its parameter tuning | |
| CN120347780B (zh) | 基于改进fwn的柔性臂空间机器人力矩双域约束控制方法 | |
| CN113650020A (zh) | 一种机械臂系统有限时间自适应镇定控制方法和系统 | |
| Polydoros et al. | Online multi-target learning of inverse dynamics models for computed-torque control of compliant manipulators | |
| CN119858164A (zh) | 输入延迟下柔性关节机器人的控制方法及系统 | |
| CN117444981A (zh) | 一种基于级联神经网络的机械臂积分滑模控制方法 | |
| CN118244807A (zh) | 一种基于智能参数自调节的动态直升机减振方法 | |
| CN113110540B (zh) | 基于时标分解的弹性体飞行器全局有限时间控制方法 | |
| CN114637213B (zh) | 一种空间组合机器人的无模型自适应预设控制方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21842446 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 21842446 Country of ref document: EP Kind code of ref document: A1 |