WO2021124648A1 - 無線コネクタ着脱方法、ロボット装置及び無線コネクタ - Google Patents
無線コネクタ着脱方法、ロボット装置及び無線コネクタ Download PDFInfo
- Publication number
- WO2021124648A1 WO2021124648A1 PCT/JP2020/037580 JP2020037580W WO2021124648A1 WO 2021124648 A1 WO2021124648 A1 WO 2021124648A1 JP 2020037580 W JP2020037580 W JP 2020037580W WO 2021124648 A1 WO2021124648 A1 WO 2021124648A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- transmission
- unit
- connector
- reception unit
- transmitting
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images







Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J19/00—Accessories fitted to manipulators, e.g. for monitoring, for viewing; Safety devices combined with or specially adapted for use in connection with manipulators
- B25J19/0025—Means for supplying energy to the end effector
- B25J19/0045—Contactless power transmission, e.g. by magnetic induction
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02J—ELECTRIC POWER NETWORKS; CIRCUIT ARRANGEMENTS OR SYSTEMS FOR SUPPLYING OR DISTRIBUTING ELECTRIC POWER; SYSTEMS FOR STORING ELECTRIC ENERGY
- H02J50/00—Circuit arrangements or systems for wireless supply or distribution of electric power
- H02J50/10—Circuit arrangements or systems for wireless supply or distribution of electric power using inductive coupling
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02J—ELECTRIC POWER NETWORKS; CIRCUIT ARRANGEMENTS OR SYSTEMS FOR SUPPLYING OR DISTRIBUTING ELECTRIC POWER; SYSTEMS FOR STORING ELECTRIC ENERGY
- H02J50/00—Circuit arrangements or systems for wireless supply or distribution of electric power
- H02J50/90—Circuit arrangements or systems for wireless supply or distribution of electric power involving detection or optimisation of position, e.g. alignment
Definitions
- the present invention relates to a wireless connector attachment / detachment method, a robot device, and a wireless connector.
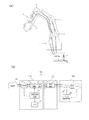
- Cited Document 1 discloses an example in which wireless power feeding units IHU2 and IHU4 are provided in the joints J2 and J4 of the robot arm device, respectively, as shown in FIG. 17A.
- the wireless power supply units IHU2 and IHU4 wirelessly transmit electric power at the joints J2 and J4 via a pair of coils.
- the wireless power supply unit 100 (corresponding to the wireless power supply unit IHU2) includes a power transmission device 10 and a reception device 20 as shown in FIG. 17 (b).
- the power transmission device 10 includes a power transmission antenna 11 including a coil and the like, an inverter circuit 13, and a power transmission control circuit 15.
- the receiving device 20 includes a power receiving antenna 21 including a coil and the like, and a rectifier circuit 23.
- the coil for transmitting and receiving electric power wirelessly often generates heat during operation, and the wireless power supply unit 100 may malfunction due to the heat generated by the coil. Since a malfunction of the wireless power supply unit 100 may interfere with the operation of the robot arm device, it is desirable that the wireless power supply unit 100 can be easily repaired by replacing the wireless power supply unit 100 or the like.
- Cited Document 1 does not disclose how the wireless power feeding unit 100 is provided in the joints J2 and J4, such as the arrangement of a pair of coils. Therefore, even with reference to Reference 1, it is difficult to obtain a wireless power supply unit 100 that can be easily repaired.
- the present invention has been made in view of such circumstances, and an object of the present invention is to provide a wireless connector that can be easily repaired.
- the wireless connector attachment / detachment method is The first object is a wireless connector for wirelessly transmitting a transmission object which is at least one of power and information between a first object and a second object rotatably connected with a rotation axis as a fulcrum.
- the wireless connector is A first transmission / reception unit for wirelessly transmitting the transmission target, and a first housing in which a first connector portion for transmitting the transmission target with the first object is fixed.
- a second transmission / reception unit for wirelessly transmitting the transmission target with the first transmission / reception unit and a second connector unit for transmitting the transmission target with the second transmission / reception object are fixed.
- the first transmission / reception is performed by attaching the first connector portion to the first object from the outside of the first object and attaching the second connector portion to the second object from the outside of the second object. Attaching the wireless connector to the first object and the second object in a state where the unit and the second transmitting / receiving unit are separated from each other and face each other so as to transmit the transmission object wirelessly.
- Removing the first connector portion from the first object by working outside the first object, and removing the second connector portion from the second object by working outside the second object. Includes removing the wireless connector from the first object and the second object.
- the robot device is The first arm portion and the second arm portion connected via a joint mechanism rotatably connected with the rotation axis as a fulcrum, A wireless connector for wirelessly transmitting a transmission target, which is at least one of electric power and information, is provided between the first arm portion and the second arm portion.
- the first arm portion includes a first mating connector portion exposed to the outside of the first arm portion.
- the second arm portion includes a second mating connector portion exposed to the outside of the second arm portion.
- the wireless connector is A first transmitter / receiver for wirelessly transmitting the transmission target and a first connector for transmitting the transmission target to and from the first object by being detachably attached to the first mating connector.
- the first transmission / reception unit and the second transmission / reception unit are described when the first connector portion and the second connector portion are attached to the first mating connector portion and the second mating connector portion, respectively. It is arranged in a state of being separated from each other and facing each other along the rotation axis so that the transmission target is transmitted wirelessly outside the joint mechanism.
- the wireless connector according to the third aspect of the present invention is A wireless connector for wirelessly transmitting a first transmission target, which is electric power, between a first object and a second object.
- a first unit that is detachably attached to the first object from the outside of the first object, A second unit that can be detachably attached to the second object from the outside of the second object is provided.
- the first unit is A first transmission / reception unit for wirelessly transmitting the first transmission target, and A first connector portion for transmitting the first transmission object to and from the first object by being detachably attached to the first object from the outside of the first object.
- the first housing to which the first transmission / reception portion and the first connector portion are fixed is included.
- the second unit is A second transmission / reception unit for wirelessly transmitting the first transmission target between the first transmission / reception unit and the first transmission / reception unit.
- a second connector portion for transmitting the first transmission object to and from the second object by being detachably attached to the second object from the outside of the second object, and
- a second housing to which the second transmission / reception portion and the second connector portion are fixed is included.
- the first transmission / reception unit and the second transmission / reception unit transfer the first transmission target when the first unit and the second unit are attached to the first object and the second object, respectively. They are arranged in a state of being separated from each other and facing each other so as to be transmitted wirelessly.
- the first transmission / reception unit includes a flat plate-shaped first coil member for transmitting the first transmission target.
- the second transmission / reception unit includes a flat plate-shaped second coil member for transmitting the first transmission target by magnetically coupling with the first coil member.
- the first coil member and the second coil member transfer the first transmission target when the first unit and the second unit are attached to the first object and the second object, respectively. They may be arranged in parallel in a state of being separated from each other and facing each other so as to be transmitted wirelessly.
- the first unit is It is fixed to the first housing and further includes a third transmission / reception unit for wirelessly transmitting a second transmission target which is information.
- the second unit is It is fixed to the second housing, and further includes a fourth transmission / reception unit for wirelessly transmitting the second transmission target with the third transmission / reception unit.
- the first connector portion transmits the first transmission target and the second transmission target to and from the first object by being detachably attached to the first object from the outside of the first object.
- the second connector portion transmits the first transmission target and the second transmission target to and from the second object by being detachably attached to the second object from the outside of the second object.
- the third transmission / reception unit and the fourth transmission / reception unit transfer the second transmission target when the first unit and the second unit are attached to the first object and the second object, respectively. They may be arranged so as to be separated from each other and opposed to each other so as to be transmitted wirelessly.
- the third transmission / reception unit includes a first antenna member for transmitting the second transmission target, which is information.
- the fourth transmission / reception unit includes a second antenna member for transmitting the second transmission target, and includes a second antenna member.
- the first transmission / reception unit is provided around the third transmission / reception unit, and the second transmission / reception unit is provided around the fourth transmission / reception unit.
- the first antenna member and the second antenna member transfer the second transmission target when the first unit and the second unit are attached to the first object and the second object, respectively. They may be arranged in parallel in a state of being separated from each other and facing each other so as to be transmitted wirelessly.
- the wireless connector according to the fourth aspect of the present invention is A wireless connector for wirelessly transmitting at least one of electric power and information to be transmitted between a first object and a second object.
- a second unit that can be detachably attached to the second object from the outside of the second object is provided.
- the first unit is A first transmission / reception unit including a first coil member for wirelessly transmitting the transmission target, and a first transmission / reception unit.
- a first that is detachably attached to the first object so as to transmit the transmission object to and from the first object by being fitted to the first object from the outside of the first object.
- the second unit is A second transmission / reception unit including a second coil member for wirelessly transmitting the transmission target to and from the first coil member.
- a second object that is detachably attached to the second object so as to transmit the transmission object to and from the second object by being fitted to the second object from the outside of the second object.
- Connector part and A second housing to which the second coil member and the second connector portion are fixed is included.
- the first connector portion and the second connector portion are fitted in the same direction.
- the first coil member and the second coil member are magnetically coupled by being arranged in a state of being separated from each other and facing each other along the fitting direction.
- the first coil member is arranged around the first central axis.
- the second coil member is arranged around the second central axis.
- the first central axis and the second central axis may be parallel to the fitting direction.
- the wireless connector according to the fifth aspect of the present invention is A wireless connector for wirelessly transmitting at least one of electric power and information to be transmitted between a first object and a second object.
- a first unit that is detachably attached to the first object from the outside of the first object, A second unit that can be detachably attached to the second object from the outside of the second object is provided.
- the first unit is A first transmission / reception unit including a first coil member for wirelessly transmitting the transmission target, and a first transmission / reception unit.
- the second unit is A second transmission / reception unit including a second coil member for wirelessly transmitting the transmission target to and from the first transmission / reception unit.
- a second connector portion for transmitting the transmission object to and from the second object by being detachably attached to the second object from the outside of the second object, and
- a second housing to which the second transmission / reception portion and the second connector portion are fixed is included.
- the first coil member and the second coil member are separated from each other and face each other in a state of being magnetically coupled to each other.
- the wireless connector according to the sixth aspect of the present invention is A wireless connector for wirelessly transmitting a transmission object, which is at least one of electric power and information, between a first object and a second object.
- the first unit is A first transmitter / receiver for wirelessly transmitting the transmission target, A first connector portion for transmitting the transmission object to and from the first object by being attached to the first object, and
- the first housing to which the first transmitter / receiver is fixed and the first connector is attached is included.
- the second unit is A second transmission / reception unit for wirelessly transmitting the transmission target with the first transmission / reception unit, A second connector portion for transmitting the transmission object to and from the second object by being attached to the second object, and Including a second housing in which the second transmitter / receiver is fixed and the second connector is attached.
- the first transmission / reception unit and the second transmission / reception unit wirelessly transmit the transmission target when the first unit and the second unit are attached to the first object and the second object, respectively. They are arranged opposite each other so as to transmit.
- the first object and the second object may be rotatably connected with the rotation axis as a fulcrum.
- the first transmission / reception unit and the second transmission / reception unit are along the rotation axis when the first unit and the second unit are attached to the first object and the second object, respectively. They may be arranged so as to face each other while being separated from each other.
- the first unit and the second unit may be separated from each other when attached to each of the first object and the second object.
- the relative positional relationship between the first transmitter / receiver and the second transmitter / receiver May further include a guide mechanism that limits the number to a predetermined range.
- the wireless connector can be easily repaired.
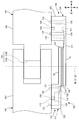
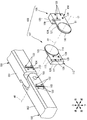
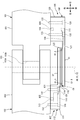
- FIG. 5 is a view of the wireless connectors attached to the first arm portion and the second arm portion according to the first embodiment as viewed from above. It is an exploded perspective view of the 1st arm part, the 2nd arm part and the wireless connector which concerns on Embodiment 1.
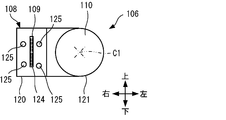
- FIG. It is a figure which looked at the 1st unit which concerns on Embodiment 1 from the rear.
- A) is a view of the second unit according to the first embodiment viewed from the front
- (b) is a view of the second unit according to the first embodiment viewed from the rear.
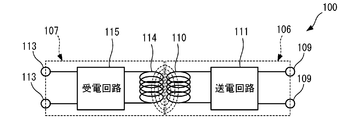
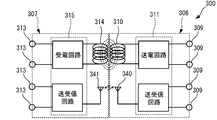
- FIG. It is a circuit block diagram in the wireless connector which concerns on Embodiment 1.
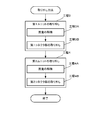
- FIG. It is a figure which shows the flow of the attachment method of the wireless connector which concerns on Embodiment 1.
- FIG. It is a figure which shows the flow of the removal method of the wireless connector which concerns on Embodiment 1.
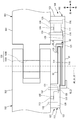
- FIG. It is the figure which looked at the wireless connector attached to the 1st arm part and 2nd arm part which concerns on modification 1 from above. It is the figure which looked at the wireless connector attached to the 1st arm part and 2nd arm part which concerns on the modification 2 from above. It is the figure which looked at the wireless connector attached to the 1st arm part and 2nd arm part which concerns on the modification 3 from above.
- FIG. (A) is a diagram showing a configuration of a robot arm device according to a related technique
- (b) is a diagram showing a circuit configuration in the robot arm device.
- Embodiment 1 (Configuration of Wireless Connector 100 According to Embodiment 1)
- the wireless connector 100 according to the first embodiment of the present invention has a first arm portion 101 and a second arm portion 102 as shown in a perspective view of FIG. 1, a plan view of FIG. 2, and an exploded perspective view of FIG. It is a connector for wirelessly transmitting power between them.
- the wireless connector 100 is detachably attached to the outside of the first arm portion 101 and the second arm portion 102.
- magnetic field coupling specifically, electromagnetic induction
- the arm portions 101 and 102 are connected via a joint mechanism 103 in a robot device such as an industrial robot or a humanoid robot.
- a robot device such as an industrial robot or a humanoid robot.
- arm portions 101, 102 is a general term for the first arm portion 101 and the second arm portion 102, and the same applies hereinafter.
- the arm portions 101 and 102 are covered by the outer shells OS1 and OS2, respectively, and their internal mechanisms and wiring are not exposed.
- the joint mechanism 103 is a mechanism that rotatably connects the first arm portion 101 and the second arm portion 102 with the rotation axis AR as a fulcrum. As a result, the first arm portion 101 and the second arm portion 102 are flexibly connected to each other.
- the joint mechanism 103 is configured such that, for example, the shaft portion 103A fixed to the second arm portion 102 and the hole portion 103B provided in the first arm portion 101 are fitted to each other.
- the joint mechanism 103 connects the arm portions 101 and 102 so as to be rotatable around the axis of the shaft portion 103A as the rotation axis AR.
- first arm portion 101 or the second arm portion 102 may be on the power supply side, but in the present embodiment, the first arm portion 101 is on the power supply side and the second arm portion 102 is on the load side. This will be described by an example.
- first arm portion 101 and the second arm portion 102 are included in the industrial robot, another member (not shown) is attached to the end portion (not shown) of the first arm portion 101 on the side opposite to the joint mechanism 103. Other arms, bases, etc.) are connected. Further, another member (another arm portion, a hand portion for sandwiching parts, etc.) is connected to an end portion (not shown) of the second arm portion 102 on the opposite side of the joint mechanism 103.
- the load in this case is, for example, an actuator, a control circuit, or the like mounted on the second arm portion 102 and other members connected to the second arm portion 102, in order to rotate the first arm portion 101 and the second arm portion 102.
- the direction along the rotation axis AR is defined as the front-rear direction
- the direction along the arm portions 101 and 102 is defined as the left-right direction.
- the direction in which the portions (the first transmission / reception unit 110 and the second transmission / reception unit 114, which will be described later) are opposed to each other in order to wirelessly transmit electric power in the wireless connector 100 are located forward with respect to the arm portions 101 and 102.
- the opposite direction is the rear.
- Each direction of top, bottom, left, and right is defined according to the direction seen from the front.
- the first arm portion 101 and the second arm portion 102 include a first mating connector portion 104 and a second mating connector portion 105, respectively.
- Each of the first mating connector portion 104 and the second mating connector portion 105 is a connector for transmitting electric power between the wireless connector 100 and the first arm portion 101 and the second arm portion 102, respectively. It is provided exposed to the outside.
- Each of the first mating connector portion 104 and the second mating connector portion 105 according to the present embodiment is a male side electric connector including a plurality of electric contacts arranged at intervals in the vertical direction.
- the first mating connector portion 104 is provided on the right side of the rotation shaft AR, and protrudes forward from the front surface of the outer shell OS1 of the first arm portion 101.
- the second mating connector portion 105 is provided on the left side of the rotation shaft AR, and projects forward from the front surface of the outer shell OS 2 of the second arm portion 102.
- the wireless connector 100 includes a first unit 106 and a second unit 107 that are detachably attached to the first arm portion 101 and the second arm portion 102, respectively.
- the first unit 106 and the second unit 107 according to the present embodiment are separated from each other without contacting each other. Therefore, when the first unit 106 and the second unit 107 are attached to the first arm portion 101 and the second arm portion 102, respectively, they can rotate relatively about the rotation axis AR.
- the first unit 106 includes a first housing 108, a first connector unit 109, a first transmission / reception unit 110, and a first circuit unit 111. .. In FIG. 4, the first bolt 128, which will be described later, is not shown.
- the second unit 107 includes components 112 to 115 corresponding to each of the components 108 to 111 included in the first unit 106.
- the second unit 107 includes a second housing 112, a second connector unit 113, a second transmission / reception unit 114, and a second circuit unit 115.
- FIGS. 5A and 5B are views of the second unit 107 viewed from the front and the rear, respectively, and in these, the second bolt 129, which will be described later, is not shown.
- the first housing 108 and the second housing 112 are members to which other components 109 to 111 and 113 to 115 included in the first unit 106 and the second unit 107 are attached, and are typically. It is made of hollow resin.
- the first housing 108 includes a first arm mounting portion 120 for mounting on the first arm portion 101 and a first facing portion 121.
- the second housing 112 is arranged so that the second arm mounting portion 122 for mounting on the second arm portion 102 and the first facing portion 121 are separated from each other along the rotation axis AR and face each other. Includes 123 and.
- Each of the first arm mounting portion 120 and the second arm mounting portion 122 has a substantially rectangular parallelepiped outer shape.
- the first arm mounting portion 120 and the second arm mounting portion 122 have substantially the same size except for the length in the front-rear direction, and the length in the front-rear direction is larger in the first arm mounting portion 120 than in the second arm. It is longer than the mounting part 122.
- the first arm mounting portion 120 includes a first opening 124 and four first bolt holes 125.
- the second arm mounting portion 122 includes a second opening 126 and four second bolt holes 127.
- the first opening 124 and the second opening 126 are provided on the rear wall portion so as to connect the internal spaces of the first arm mounting portion 120 and the second arm mounting portion 122 to the outside.
- a first connector portion 109 and a second connector portion 113 are provided on the inner side (front side) of the first opening 124 and the inner side (front side) of the second opening 126, respectively.
- Each of the first bolt hole 125 and the second bolt hole 127 is a through hole in the front-rear direction.
- the first bolt 128 for fixing the first housing 108 to the first arm portion 101 is arranged in the first bolt hole 125 in a state of being penetrated.
- the second bolt hole 127 is arranged with the second bolt 129 for fixing the second housing 112 to the second arm portion 102 penetrating.
- the first facing portion 121 and the second facing portion 123 have a flat plate shape in which their respective base ends are connected to the left end of the first arm mounting portion 120 and the right end of the second arm mounting portion 122 and extend in a direction close to each other. It is a part. As a result, the first facing portion 121 and the second facing portion 123 face each other apart from each other along the rotation axis AR.
- the first confrontation portion 121 has a base end connected to the left end of the first arm mounting portion 120, and extends to the left from the base end so that the front surface is flush with the front surface of the first arm mounting portion 120.
- the first facing portion 121 extends from the base end at a constant height substantially the same as the height of the first arm mounting portion 120, and has a semicircular shape in which the tip protrudes to the left when viewed from the front.
- the "height" is a length in the vertical direction, and the same applies to the following.
- the second arm mounting portion 123 has a base end connected to the right end of the second arm mounting portion 122, and extends to the right from the base end so that the front surface is flush with the front surface of the second arm mounting portion 122.
- the second facing portion 123 extends from the base end at a constant height substantially the same as the height of the second arm mounting portion 122, and has a semicircular shape in which the tip protrudes to the right when viewed from the front.
- the thickness of the first facing portion 121 is thinner than the difference in thickness between the first arm mounting portion 120 and the second arm mounting portion 122.
- the tips of the first facing portion 121 are arranged in front of the second facing portion 123 at intervals.
- the first confrontation portion 121 and the second confrontation portion 123 are arranged in a state in which a substantially circular region including their respective tips is separated from each other and faces each other along the rotation axis AR outside the joint mechanism 103.
- the thickness of the second facing portion 123 may be appropriately set, but it is thinner than the second arm mounting portion 122, and is substantially the same as the thickness of the first facing portion 121 in the present embodiment.
- the "thickness" is the length in the front-rear direction, and the same applies to the following.
- the first connector portion 109 is a portion for transmitting electric power to and from the first arm portion 101.
- the first connector portion 109 is detachably attached to the first arm portion 101 from the outside of the first arm portion 101.
- the first connector portion 109 is attached to the first mating connector portion 104 to transmit electric power to and from the first arm portion 101.
- the first connector portion 109 is a female-side electric connector fixed to the first housing 108, and a plurality of electric connectors arranged in front of the first opening 124 at intervals in the vertical direction. Including contacts.
- the first connector portion 109 is exposed to the outside of the first housing 108 through the first opening 124, so that the first connector portion 109 is inserted from the rear of the first housing 108 through the first opening 124 in the front-rear direction. Fit each other.
- the first connector portion 109 and the first mating connector portion 104 that are fitted to each other can be electrically connected to each other by contact with each other and transmit electric power.
- the relationship between the female side and the male side of the first connector portion 109 and the first mating connector portion 104 may be interchanged.
- the first mating connector portion 104 may be exposed to the outside of the first arm portion 101 even when it is on the female side, whereby the first connector portion 109 can be detachably attached from the outside of the first arm portion 101. be able to.
- an opening may be provided in the outer shell OS1 of the first arm portion 101, and an electrical contact constituting the first mating connector portion 104 may be provided inside the opening.
- the second connector portion 113 is a portion for transmitting electric power to and from the second arm portion 102.
- the second connector portion 113 is detachably attached to the second arm portion 102 from the outside of the second arm portion 102.
- the second connector portion 113 is attached to the second mating connector portion 105 to transmit electric power to and from the second arm portion 102.
- the second connector portion 113 is an electric connector on the female side fixed to the second housing 112, and a plurality of electric connectors arranged in front of the second opening 126 at intervals in the vertical direction. Including contacts.
- the second connector portion 113 is exposed to the outside of the second housing 112 through the second opening 126, so that the second connector portion 113 is inserted from the rear of the second housing 112 through the second opening 126 in the front-rear direction. Fit each other.
- the second connector portion 113 and the second mating connector portion 105 that are fitted to each other can be electrically connected to each other by contact with each other and transmit electric power.
- the relationship between the female side and the male side of the second connector portion 113 and the second mating connector portion 105 may be interchanged.
- the second mating connector portion 105 may be exposed to the outside of the second arm portion 102 even when it is on the female side, whereby the second connector portion 113 can be detachably attached from the outside of the second arm portion 102. be able to.
- an opening may be provided in the outer shell OS 2 of the second arm portion 102, and an electrical contact constituting the second mating connector portion 105 may be provided inside the opening.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 are members for wirelessly transmitting electric power between them, and are along the rotation axis AR outside the joint mechanism 103 so as to transmit electric power wirelessly. They are arranged so as to be separated from each other and face each other.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 have a shape centered on the first central axis C1 and the second central axis C2, respectively, and are, for example, disk-shaped.
- the first transmission / reception unit 110 is fixed to the outer surface behind the first confrontation portion 121 with, for example, an adhesive or a screw so that the outer edge thereof substantially coincides with the tip of the first confrontation portion 121. ..
- the second transmitting / receiving portion 114 is fixed to the outer surface in front of the second facing portion 123 with, for example, an adhesive or a screw so that its outer edge substantially coincides with the tip of the second facing portion 123.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 are fixed to regions facing each other along the respective rotation axes AR of the first confrontation unit 121 and the second confrontation unit 123. Therefore, the first transmission / reception unit 110 and the second transmission / reception unit 114 are arranged outside the joint mechanism 103 along the rotation axis AR so as to face each other. Further, the first transmission / reception unit 110 and the second transmission / reception unit 114 are arranged in a state of being separated from each other without contacting each other, and preferably are arranged in parallel with each other so as to face a direction perpendicular to the rotation axis AR.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 are a disk-shaped first coil member and a second coil member having substantially the same size, respectively. That is, the first coil member has a disk shape centered on the first central axis C1. The second coil member has a disk shape centered on the second central axis C2.
- Each of the first coil member and the second coil member is, for example, a conductor wound spirally around the central axis C1 or C2, and a printed circuit board printed spirally around the central axis C1 or C2. It may be composed of wiring or the like.
- first coil member and the second coil member are arranged so as to face each other along the rotation axis AR, they are magnetically coupled by electromagnetic induction. As a result, electric power can be wirelessly transmitted between the first coil member and the second coil member.
- the area (opposite area) of the regions facing each other is large. It is preferable that the three axes AR, C1 and C2 coincide with each other. However, if the first transmission / reception unit 110 and the second transmission / reception unit 114 are arranged so as to transmit electric power (in the present embodiment, so as to be magnetically coupled) so as to face each other along the rotation axis AR. Often, the three axes AR, C1 and C2 may be misaligned due to manufacturing errors, design restrictions, and the like.
- sheet-shaped shield members S1 and S2 made of metal, soft magnetic material, or the like are provided at the front of the first transmission / reception unit 110 and the rear of the second transmission / reception unit 114, respectively. ing. As a result, the first transmission / reception unit 110 and the second transmission / reception unit 114 are sandwiched between the shield members S1 and S2 along the rotation axis AR, so that electromagnetic waves emitted to the outside can be suppressed.
- the first transmission / reception unit 110 may further include a capacitor or the like connected in series or in parallel with the first coil member, or may further include a resin case in which the first coil member or the like is housed.
- the second transmission / reception unit 114 may further include a capacitor or the like connected in series or in parallel with the second coil member, or may further include a resin case in which the second coil member or the like is housed.
- the first circuit unit 111 is an electric circuit that is electrically connected to the first connector unit 109 and the first transmission / reception unit 110.
- the first circuit unit 111 is fixed to the inside of the first housing 108 in a state of being electrically connected to each of the first connector unit 109 and the first transmission / reception unit 110.
- the first circuit unit 111 is fixed to the front end of the first connector unit 109, and is electrically connected to the first transmission / reception unit 110 via the first conductor 130.
- the first circuit unit 111 is a power transmission circuit, for example, an inverter circuit that converts the electric power supplied from the first arm unit 101 through the first connector unit 109 into electric power for outputting to the first transmission / reception unit 110. including.
- the second circuit unit 115 is an electric circuit that is electrically connected to the second connector unit 113 and the second transmission / reception unit 114.
- the second circuit unit 115 is fixed to the inside of the second housing 112 in a state of being electrically connected to each other of the second connector unit 113 and the second transmission / reception unit 114.
- the second circuit unit 115 is fixed to the front end of the second connector unit 113, and is electrically connected to the second transmission / reception unit 114 via the first conductor 131.
- the second circuit unit 115 is a power receiving circuit, and for example, the power received by the second transmitting / receiving unit 114 magnetically coupled to the first transmitting / receiving unit 110 is output to the second arm unit 102 through the second connector unit 113.
- the design rotation axes (for example, the first central axis C1 and the second unit 107) are used.
- the axis that coincides with the central axis C2 of) may not coincide with the rotation axis AR.
- the first unit 106 and the second unit 107 according to the present embodiment are separated from each other without contacting each other. Therefore, even if the design rotation axis deviates from the rotation axis AR, it can rotate about the rotation axis AR as the arm portions 101 and 102 bend.
- first unit 106 and the second unit 107 are separated from each other without contacting each other. Therefore, there is almost no wear even if the electric connector 100 is rotated relatively, and the durability of the electric connector 100 can be improved.
- the electric power supplied from the first arm unit 101 (power supply side) is supplied to the first transmission / reception unit 110 through the first connector unit 109 and the first circuit unit 111.
- an alternating current flows through the first transmission / reception unit 110, and a magnetic field is generated around the first transmission / reception unit 110.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 are arranged in a state of being separated from each other and facing each other along the rotation axis AR. Therefore, the first transmission / reception unit 110 and the second transmission / reception unit 114 are magnetically coupled, and an induced electromotive force corresponding to the magnetic field generated around the first transmission / reception unit 110 is generated in the second transmission / reception unit 114. That is, in the present embodiment, the first coil member constituting the first transmission / reception unit 110 functions as a power transmission coil, and the second coil member constituting the second transmission / reception unit 114 functions as a power reception coil.
- the electric power generated in the second transmission / reception unit 114 is supplied to the second arm unit 102 (load side) through the second circuit unit 115 and the second connector unit 113. In this way, the wireless connector 100 can wirelessly transmit electric power between the first arm portion 101 and the second arm portion 102.
- the arm portions 101 and 102 bend and stretch by rotating with the rotation axis AR as a fulcrum, and accordingly, the first unit 106 and the second unit 107 are centered on the rotation axis AR. Rotate to.
- transmission / reception units 110 and 114 are arranged in a state of being separated from each other and facing each other along the rotation axis AR, even when the first unit 106 and the second unit 107 rotate, they are magnetically coupled by electromagnetic induction. Therefore, regardless of the bending / stretching state of the arm portions 101 and 102, and even during the bending / stretching operation of the arm portions 101 and 102, the wireless connector 100 can operate in the same manner as described above. Electric power can be wirelessly transmitted between the 1-arm portion 101 and the 2nd arm portion 102.
- transmission / reception units 110, 114 is a general term for the first transmission / reception unit 110 and the second transmission / reception unit 114, and the same applies hereinafter.
- the transmission / reception units 110 and 114 are arranged in a state where the relative positional relationship is restricted. That is, the transmission / reception units 110 and 114 are arranged so that their relative positional relationships are within a predetermined range even when the transmission / reception units 110 and 114 are rotated about the rotation axis AR.
- the relative positional relationship between the transmission / reception units 110 and 114 includes the distance at which the transmission / reception units 110 and 114 are separated along the rotation axis AR (separation distance), the area of the regions facing each other (opposite area), and the rotation axis. The angle to be made with respect to AR.
- the transmission / reception units 110 and 114 are arranged in parallel with each other as an example of the arrangement in a state where the relative positional relationship is restricted.
- the transmission / reception units 110 and 114 By limiting the relative positional relationship between the transmission / reception units 110 and 114, the transmission / reception units 110 and 114 have a relatively stable strength within a predetermined range regardless of the bending and stretching states and bending and stretching movements of the arm units 101 and 102. It can be magnetically coupled. Therefore, even when the wireless connector 100 is arranged outside the arm portions 101 and 102, stable wireless power transmission becomes possible.
- the wireless connector attachment / detachment method is a method for attaching / detaching the wireless connector 100 to / from the arm portions 101 and 102, and includes a method of attaching / detaching the wireless connector 100 and a method of attaching / detaching the wireless connector 100.
- FIG. 7 is a flowchart showing a flow of a method of attaching the wireless connector 100.
- the method of attaching the wireless connector 100 is started by preparing a robot device including the arm portions 101 and 102 connected via the joint mechanism 103 and the wireless connector 100.
- the second unit 107 is attached to the second arm portion 102 from the outside of the second arm portion 102 (step 1; attachment step of the second unit).
- step 1 the second connector portion 113 is attached to the second arm portion 102 in a state where the second transmission / reception portion 114 is positioned in front of the joint mechanism 103 on the rotation axis AR (step 1A; Installation process of the second connector part).
- the second connector portion 113 is attached to the second arm portion 102 by fitting the second mating connector portion 105. Since the second mating connector portion 105 is exposed to the outside of the second arm portion 102, the second connector portion 113 is attached to the second arm portion 102 from the outside of the second arm portion 102.
- the second connector portion 113 By attaching the second connector portion 113 in this way, the second connector portion 113 and the second mating connector portion 105 are electrically connected. Further, in the present embodiment, since the second connector portion 113 is fixed to the second housing 112, the second housing 112 is attached to the second arm portion 102 together with the second connector portion 113. As a result, the second unit 107 is attached to the second arm portion 102.
- the second unit 107 is fixed to the second arm portion 102 (step 1B; fixing step).
- the second bolt 129 is inserted into each of the second bolt holes 127, and the second bolt hole 132 provided in the second arm portion 102 is screwed into the second housing 112. Is fixed to the second arm portion 102.
- the method of fixing the second unit 107 to the second arm portion 102 is not limited to bolting, and may be, for example, locking by catching the claw and the peripheral portion of the second opening 126.
- the first unit 106 is attached to the first arm portion 101 from the outside of the first arm portion 101 (step 2; attachment step of the first unit).
- step 2 the first connector unit 109 is attached to the first arm unit 101 in a state where the first transmission / reception unit 110 is positioned in front of the joint mechanism 103 and the second transmission / reception unit 114 on the rotation axis AR. It is attached (step 2A; attachment step of the first connector portion).
- the first connector portion 109 is attached to the first arm portion 101 by fitting the first mating connector portion 104. Since the first mating connector portion 104 is exposed to the outside of the first arm portion 101, the first connector portion 109 is attached to the first arm portion 101 from the outside of the first arm portion 101.
- the first connector portion 109 By attaching the first connector portion 109 in this way, the first connector portion 109 and the first mating connector portion 104 are electrically connected. Further, in the present embodiment, since the first connector portion 109 is fixed to the first housing 108, the first housing 108 is attached to the first arm portion 101 together with the first connector portion 109. As a result, the first unit 106 is attached to the first arm portion 101.
- the first unit 106 is fixed to the first arm portion 101 (step 2B; fixing step).
- the first housing 108 is formed by inserting the first bolt 128 into each of the first bolt holes 125 and screwing the first bolt 128 into the first bolt hole portion 133 provided in the first arm portion 101. Is fixed to the first arm portion 101.
- the method of fixing the first unit 106 to the first arm portion 101 is not limited to bolting, and may be, for example, locking by catching the claw and the peripheral portion of the first opening 124.
- the method of attaching the wireless connector 100 is completed, and the electric connector 100 is attached in a state of being fixed to the first arm portion 101 and the second arm portion 102.
- the transmission / reception units 110 and 114 face each other in a state of being separated from each other along the rotation axis AR outside the joint mechanism 103 so as to transmit power wirelessly, and face a direction substantially perpendicular to the rotation axis AR. Are arranged almost in parallel.
- FIG. 8 is a flowchart showing a flow of a method of removing the wireless connector 100.
- the method of removing the wireless connector 100 is typically performed as necessary after attaching the wireless connector 100 to the robot device by the method of attaching the wireless connector 100 described above.
- An example of a case where the wireless connector 100 needs to be removed includes a case where the defective wireless connector 100 is replaced with a normal wireless connector 100 in order to repair it.
- the first unit 106 is removed from the first arm portion 101 by working outside the first arm portion 101 (step 3; removal step of the first unit).
- step 3A fixing release step
- the first bolt 128 is removed from the first bolt hole 125 after the first bolt 128 and the first bolt hole portion 133 are disengaged by the screw action.
- the first connector portion 109 is removed from the first arm portion 101 (step 3B; removal step of the first connector portion).
- an operator grips the first housing 108 with a hand, a jig, or the like outside the first arm portion 101. Then, by pulling out the first connector portion 109 from the first mating connector portion 104, the first connector portion 109 is removed from the first arm portion 101.
- the first connector portion 109 is fixed to the first housing 108, the first housing 108 is removed from the first arm portion 101 together with the first connector portion 109. As a result, the first unit 106 is removed from the first arm portion 101.
- the second unit 107 is removed from the second arm portion 102 by working outside the second arm portion 102 (step 4; removal step of the second unit).
- step 4A fixing release step
- the second bolt 129 is removed from the second bolt hole 127 after the fitting of the second bolt 129 and the second bolt hole 132 due to the screwing action is released.
- the second connector portion 113 is removed from the second arm portion 102 (step 4B; removal step of the second connector portion).
- an operator grips the second housing 112 with a hand, a jig, or the like outside the second arm portion 102. Then, by pulling out the second connector portion 113 from the second mating connector portion 105, the second connector portion 113 is removed from the second arm portion 102.
- the second housing 112 since the second connector portion 113 is fixed to the second housing 112, the second housing 112 is removed from the first arm portion 101 together with the second connector portion 113. As a result, the second unit 107 is removed from the second arm portion 102.
- the method of removing the wireless connector 100 is completed, and the wireless connector 100 is removed from the arm portions 101 and 102.
- the wireless connector 100 can be attached to and detached from the arm portions 101 and 102 by working outside the arm portions 101 and 102. Thereby, for example, the defective wireless connector 100 can be easily replaced with a normal wireless connector 100. Therefore, the wireless connector 100 can be easily repaired.
- the wireless connector 100 is attached to the arm portions 101 and 102 in a state of being arranged outside the arm portions 101 and 102. Therefore, the influence on the internal design of the arm portions 101 and 102 is less than that in the case where the arm portions 101 and 102 are provided inside. Therefore, it is possible to improve the degree of freedom in designing the arm portions 101 and 102.
- the mating direction between the first connector portion 109 and the first mating connector portion 104 and the mating direction between the second connector portion 113 and the second mating connector portion 105 are the same before and after. The direction. Then, the transmission / reception units 110 and 114 are magnetically coupled by being arranged in a state of being separated from each other and facing each other along the fitting direction.
- the first mating connector portion 104 and the second mating connector portion 105 may be provided in opposite directions via the rotation axis AR of the joint mechanism 103. Therefore, the first mating connector portion 104 and the second mating connector portion 105 can be easily provided. Further, in the wireless connector 100, as can be seen from the above description of the configuration, the configurations of the first unit 106 and the second unit 107 can be relatively simplified.
- the wireless connector 100 can be easily provided on the arm portions 101 and 102 as a simple configuration.
- the first central axis C1 and the second central axis C2 are oriented in parallel front-rear directions, and are aligned with the fitting direction of the first connector portion 109 and the second connector portion 113. It is parallel.
- the first transmission / reception unit 110 (first coil member) and the second connector unit 113 (second coil member) can be arranged substantially parallel to each other, and can be satisfactorily coupled to the magnetic field. Therefore, it is possible to transmit electric power satisfactorily wirelessly with a simple configuration.
- the present invention is not limited to the present embodiment, and includes a modified embodiment 1 as follows.
- the wireless connector 200 includes the first unit 206 and the second unit 207 which are separated from each other without contacting each other as in the first embodiment.
- the first unit 206 includes a first transmission / reception unit 110 and a first circuit unit 111 similar to those in the first embodiment, and a first connector unit 209 and a first housing 208 different from those in the first embodiment.
- the first connector portion 209 is a portion for transmitting electric power to and from the first arm portion 101, and can be detachably attached to the first mating connector portion 104 by fitting each other. It is an electric connector that can be attached.
- the first connector portion 209 includes a first conducting wire 230 extending to the outside of the first housing 208, and is connected to the first circuit portion 111 provided inside the first housing 208 through the first conducting wire 230.
- the first housing 208 includes a first confrontational portion 121 to which the first transmission / reception portion 110 similar to the first embodiment is fixed, and a first arm mounting portion 220 different from the first embodiment.
- the first arm mounting portion 220 may be configured substantially in the same manner as the first arm mounting portion 120 according to the first embodiment, except that the first connector portion 109 is not provided inside.
- the second unit 207 includes a second transmission / reception unit 114 and a second circuit unit 115 similar to those in the first embodiment, and a second connector unit 213 and a second housing 212 different from the first embodiment.
- the second connector portion 213 is a portion for transmitting electric power to and from the second arm portion 102, and can be detachably attached to the second mating connector portion 105 by fitting each other. It is an electric connector that can be attached.
- the second connector portion 213 includes a first conducting wire 231 extending to the outside of the second housing 212, and is connected to the second circuit portion 115 provided inside the second housing 212 through the first conducting wire 231.
- the second housing 212 includes a second confrontation portion 123 to which the second transmission / reception portion 114 similar to the first embodiment is fixed, and a second arm mounting portion 222 different from the first embodiment.
- the second arm mounting portion 222 may be configured substantially in the same manner as the second arm mounting portion 122 according to the first embodiment, except that the second connector portion 113 is not provided inside.
- the transmission / reception units 110 and 114 wirelessly transmit electric power by electromagnetic induction as in the first embodiment. It is arranged outside the 103 in a state of being separated from each other and facing each other along the rotation axis AR. Therefore, according to the wireless connector 200, electric power can be wirelessly transmitted between the arm portions 101 and 102 as in the first embodiment.
- the wireless connector 200 can be attached to and detached from the arm portions 101 and 102 by working outside the arm portions 101 and 102. Thereby, for example, the defective wireless connector 200 can be easily replaced with a normal wireless connector 200. Therefore, the wireless connector 200 can be easily repaired.
- the first unit 106 and the second unit 107 are guides that limit the relative positional relationship between the transmission / reception units 110 and 114 to a predetermined range when attached to the arm units 101 and 102. It may include a mechanism.
- the guide mechanism is provided in the first unit 106 and the second unit 107, but the guide mechanism may be provided in the first arm portion 101, the second arm portion 102, and the like. ..
- the guide mechanism G1 includes a relatively small protrusion G1_A provided on the front surface of the second transmission / reception unit 114 and an annular groove G1_B provided on the rear surface of the first transmission / reception unit 110. Consists of.
- the tip of the protrusion G1_A fits into the groove G1_B and comes into contact with the bottom of the groove G1_B.
- the bottom of the groove G1_B is an annular plane with a width.
- the first unit 106 and the second unit 107 have a design rotation axis and a rotation axis AR when they are attached to the arm portions 101 and 102. Can rotate about the rotation axis AR even if is deviated.
- the relative positional relationship between the transmission / reception units 110 and 114 is limited to a predetermined range by the fitting of the protrusion G1_A and the groove G1_B. As a result, as described above, even when the wireless connector 100 is arranged outside the arm portions 101 and 102, stable wireless power transmission becomes possible.
- the guide mechanism G2 includes a first protruding portion G2_A provided in the first housing 108 and a first protruding portion G2_B provided in the second housing 112.
- the first protruding portion G2_A covers at least a part around the second facing portion 123 and at least a part behind the second facing portion 123.
- the second protruding portion G2_B covers at least a part of the periphery of the first facing portion 121 and covers at least a part of the front of the first facing portion 121.
- the first protruding portion G2_A is provided with a gap between it and the second facing portion 123.
- the second protruding portion G2_B is provided with a gap between the second protruding portion G2_B and the first facing portion 121.
- the relative movement of the second arm mounting portion 122 and the first arm mounting portion 120 is restricted by the first protruding portion G2_A and the second protruding portion G2_B, the relative movement between the transmitting / receiving portions 110 and 114 is restricted.
- the positional relationship is limited to a predetermined range. As a result, as described above, even when the wireless connector 100 is arranged outside the arm portions 101 and 102, stable wireless power transmission becomes possible.
- the guide mechanism G3 according to the modified example 4 is provided in the second transmission / reception unit 114, and has an axis portion G3_A whose axis substantially coincides with the second central axis C2 and a first transmission / reception unit. It is provided in 110, and is composed of a hole portion G3_B whose center substantially coincides with the first central axis C1.
- the shaft portion G3_A and the hole portion G3_B are loosely fitted with a gap from each other.
- the relative movement of the second arm mounting portion 122 and the first arm mounting portion 120 is restricted by the fitting of the shaft portion G3_A and the hole portion G3_B, the relative movement between the transmitting / receiving portions 110 and 114 is restricted.
- the positional relationship is limited to a predetermined range. As a result, as described above, even when the wireless connector 100 is arranged outside the arm portions 101 and 102, stable wireless power transmission becomes possible.
- the transmission target may be information or both electric power and information.
- the configurations of the first circuit unit 111 and the second circuit unit 115 of the wireless connector 100 according to the present embodiment may be changed according to the transmission target.
- the object to which the wireless connector 100 is attached is not limited to the robot device.
- the first arm portion 101 is an example of a first object to which the first unit 106 is attached
- the second arm portion 102 is an example of a second object to which the second unit 107 is attached.
- the first object and the second object need only be rotatably connected with the rotation axis AR as a fulcrum, and are typically mounted on various devices and devices, each of which is mounted on the first arm portion 101. And has a length like the second arm portion 102.
- the transmission means to be transmitted between the transmission / reception units 110 and 114 is electromagnetic induction
- the transmission means is not limited to electromagnetic induction, which is an aspect of magnetic field coupling.
- the transmission means may be, for example, magnetic resonance, which is another aspect of magnetic field coupling, electric field coupling similar to that between electrodes constituting a capacitor, transmission / reception of electromagnetic waves such as microwaves and light, and the like. ..
- the configurations of the first transmission / reception unit 110, the second transmission / reception unit 114, the first circuit unit 111, the second circuit unit 115, and the like may be changed according to the transmission means between the transmission / reception units 110 and 114.
- the first transmission / reception unit 110 is provided on the outer surface behind the left end of the first confrontation unit 121, and the second transmission / reception unit 114 is provided on the outer surface in front of the right end of the second confrontation unit 123.
- the location where the first transmission / reception unit 110 and the second transmission / reception unit 114 are provided is not limited to these.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 may be separated from each other and face each other in a state in which the transmission target is wirelessly transmitted.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 may be provided on the wall portions of the first housing 108 and the second housing 112, which are close to each other.
- the first transmission / reception unit 110 may be fixed to the inner surface behind the left end of the first confrontation unit 121 (that is, rearward inside the first confrontation unit 121), and may be fixed to the rear left end of the first confrontation unit 121.
- a hole may be provided in the hole and fitted into the hole to be fixed.
- the second transmission / reception unit 114 may be fixed to the inner surface in front of the right end of the second confrontation unit 123 (that is, the front inside the second confrontation unit 123), and the left end of the second confrontation unit 123. It may be fixed by being fitted into a hole provided at the rear.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 have been described by an example in which they have a disk shape.
- the shape of each of the first transmission / reception unit 110 and the second transmission / reception unit 114 is not limited to the disk shape, and may be a flat plate shape having other shapes.
- the first transmission / reception unit 110 and the second transmission / reception unit 114 are not limited to a flat plate shape, and are, for example, a mountain shape having an apex on the first central axis C1 and a valley shape having a bottom on the second central axis C2. It may be a complementary three-dimensional shape or the like.
- the shapes of the first coil member and the second coil member included in the first transmission / reception unit 110 and the second transmission / reception unit 114 are not limited to the disk shape, but are flat plates and complementary shapes of other shapes. It may have a three-dimensional shape or the like.
- the first connector portion and the first mating connector portion are not limited to electric connectors, and are elements, components, etc. for wirelessly transmitting power by, for example, magnetic field coupling, electric field coupling, transmission / reception of electromagnetic waves such as microwaves and light. It may be composed of.
- the second connector portion 113 and the second mating connector portion 105 may be configured to transmit electric power wirelessly.
- first unit 106 and the second unit 107 are structurally separated has been described as an example.
- first unit 106 and the second unit 107 are not structurally separated and may be loosely connected.
- the first unit 106 and the second unit 107 can be connected by further deforming the shaft portion and the hole portion that are loosely fitted to each other as described in the modification example 4. That is, it is preferable that the hole portion is arranged so that the hole portion penetrates the first transmission / reception portion 110 and the first confrontation portion 121, and the shaft portion penetrates the hole portion. Then, it is preferable that the tip of the shaft portion is provided with a protrusion portion that projects with a radius larger than that of the hole portion. Since the protrusion is locked to the hole, the first unit 106 and the second unit 107 are connected. However, the shaft portion and the hole portion are loosely fitted with each other at a distance.
- the rotation axis AR can be changed. Can rotate around the center. Further, since the relative positional relationship between the transmission / reception units 110 and 114 is limited to a predetermined range, the case where the wireless connector 100 is arranged outside the arm units 101 and 102 is the same as in the modified example 4. However, stable wireless power transmission becomes possible.
- Embodiment 2 In the first embodiment, an example in which the wireless connector 100 wirelessly transmits electric power by including the transmission / reception units 110 and 114 has been described. In the present embodiment, an example of a wireless connector including a third transmission / reception unit and a fourth transmission / reception unit for transmitting information in addition to the first transmission / reception unit and the second transmission / reception unit for transmitting electric power will be described.
- the electric power according to the present embodiment is an example of a first transmission target which is at least one of electric power and information
- the information is an example of a second transmission object which is at least one of electric power and information.
- the wireless connector 300 (Configuration of Wireless Connector 300 According to Embodiment 2) As shown in the exploded perspective view of FIG. 13, the wireless connector 300 according to the second embodiment of the present invention has power and power and power between the first arm portion 101 and the second arm portion 102 similar to those of the first embodiment. It is a connector for transmitting information wirelessly.
- the wireless connector 300 is detachably attached to the outside of the arm portions 101 and 102. In this embodiment, an example of wirelessly transmitting electric power and information by magnetic field coupling (electromagnetic induction) and electromagnetic waves will be described.
- the wireless connector 300 includes a first unit 306 and a second unit 307 that are detachably attached to the first arm portion 101 and the second arm portion 102, respectively.
- the first unit 306 and the second unit 307 are separated from each other without contacting each other, as in the first embodiment.
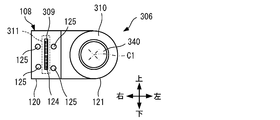
- the first unit 306 includes a first housing 108 similar to that of the first embodiment, a first connector portion 309 different from that of the first embodiment, and a first transmission / reception unit. Includes 310 and first circuit section 311. Further, the first unit 306 includes a third transmission / reception unit 340. In FIG. 14, the first bolt 128 similar to that of the first embodiment is not shown.
- the second unit 307 is a component 112, 313 to 315, 341 corresponding to each of the components 108, 309 to 311, 340 included in the first unit 306. including.
- the second unit 307 includes a second housing 112 similar to the first embodiment, a second connector unit 313 different from the first embodiment, a second transmission / reception unit 314, and a second circuit unit 315.
- the first unit 306 includes a fourth transmission / reception unit 341.
- the second bolt 129 which is the same as that of the first embodiment, is not shown.
- the first connector portion 309 is a portion for transmitting electric power and information to and from the first arm portion 101.
- the first connector portion 309 is detachably attached to the first arm portion 101 from the outside of the first arm portion 101 to transmit electric power and information to and from the first arm portion 101.
- the first connector portion 309 has substantially the same configuration as the first connector portion 109 according to the first embodiment, except that it includes an electric contact for transmitting information in addition to an electric contact for transmitting electric power. It should be done.
- the second connector portion 313 is a portion for transmitting electric power and information to and from the second arm portion 102.
- the second connector portion 313 is detachably attached to the second arm portion 102 from the outside of the second arm portion 102 to transmit electric power and information to and from the second arm portion 102.
- the second connector portion 313 has substantially the same configuration as the second connector portion 113 according to the first embodiment, except that it includes an electric contact for transmitting information in addition to an electric contact for transmitting electric power. It should be done.
- the first transmission / reception unit 310 and the second transmission / reception unit 314 are members for wirelessly transmitting electric power between them, and are along the rotation axis AR outside the joint mechanism 103 so as to transmit electric power wirelessly. They are arranged so as to be separated from each other and face each other.
- the first transmission / reception unit 310 and the second transmission / reception unit 314 have a shape centered on the first central axis C1 and the second central axis C2, respectively, and are, for example, hollow discs. is there.
- the first transmission / reception unit 310 and the second transmission / reception unit 314 may be configured in the same manner as the first transmission / reception unit 110 and the second transmission / reception unit 114 according to the first embodiment, except that they are hollow. .. That is, the first transmission / reception unit 310 and the second transmission / reception unit 314 according to the present embodiment are a hollow disk-shaped first coil member and a second coil member, respectively.
- the third transmission / reception unit 340 and the fourth transmission / reception unit 341 are members for wirelessly transmitting information between them, and are along the rotation axis AR outside the joint mechanism 103 so as to transmit information wirelessly. They are arranged so as to be separated from each other and face each other.
- the third transmission / reception unit 340 and the second transmission / reception unit 321 have a shape centered on the first central axis C1 and the second central axis C2, respectively, and are, for example, disk-shaped.
- the third transmission / reception unit 340 and the fourth transmission / reception unit 341 are provided inside the first transmission / reception unit 310 and the second transmission / reception unit 314, respectively.
- the first transmission / reception unit 310 is provided around the third transmission / reception unit 340 with the first central axis C1 that is generally common as the center.
- the second transmission / reception unit 314 is provided around the fourth transmission / reception unit 341 with the second central axis C2, which is generally common, as the center.
- the third transmission / reception unit 340 and the fourth transmission / reception unit 341 are the same as those of the first transmission / reception unit 110 and the second transmission / reception unit 114 according to the first embodiment, except for the location where they are arranged and the transmission method. It should be configured. That is, the third transmission / reception unit 340 and the fourth transmission / reception unit 341 according to the present embodiment are a disk-shaped first antenna member and a second antenna member, respectively.
- the first circuit unit 311 is an electric circuit that is electrically connected to the first connector unit 309, the first transmission / reception unit 310, and the third transmission / reception unit 340.
- the first circuit unit 311 may be configured substantially in the same manner as the first circuit unit 111 according to the first embodiment, except that it further includes an information transmission / reception circuit for transmitting and / or receiving information.
- “transmitting and / or receiving” means performing one or both of transmission and reception, and the same applies to the following.
- the second circuit unit 315 is an electric circuit that is electrically connected to the second connector unit 313, the second transmission / reception unit 314, and the fourth transmission / reception unit 341.
- the second circuit unit 315 may be configured substantially in the same manner as the second circuit unit 115 according to the first embodiment, except that it further includes an information transmission / reception circuit for transmitting and / or receiving information.
- the first unit 306 and the second unit 307 are separated from each other without contacting each other. Therefore, as in the first embodiment, when the first unit 306 and the second unit 307 are attached to the arm portions 101 and 102, even if the design rotation axis deviates from the rotation axis AR, the arms It can rotate about the rotation axis AR as the portions 101 and 102 bend.
- the transmission / reception units 310 and 314 are arranged in a state of being separated from each other and facing each other along the rotation axis AR.
- the first transmission / reception unit 110 connected to the power transmission circuit included in the first circuit unit 311 and the second transmission / reception unit 314 connected to the power reception circuit included in the second circuit unit 315. Can be magnetically coupled by electromagnetic induction. Therefore, by operating in the same manner as the wireless connector 100 described with reference to FIG. 6, electric power can be wirelessly transmitted between the first arm portion 101 and the second arm portion 102.
- transmission / reception unit 310, 314" is a general term for the first transmission / reception unit 310 and the second transmission / reception unit 314, and the same applies hereinafter.
- the transmission / reception units 310 and 314 are arranged in a state of being separated from each other and facing each other along the rotation axis AR, even when the first unit 106 and the second unit 107 rotate about the rotation axis AR, the electromagnetic wave is transmitted. Magnetic field coupling by induction. As a result, the wireless connector 300 becomes the first arm portion 101 and the second arm portion 102 regardless of the bending / stretching state and operation of the arm portions 101 and 102, similarly to the transmission / reception portions 110 and 114 according to the first embodiment. Power can be transmitted wirelessly between them.
- transmission / reception unit 340, 341 is a general term for the third transmission / reception unit 340 and the fourth transmission / reception unit 341, and the same applies hereinafter.
- the transmission / reception units 340 and 341 are arranged in a state of being separated from each other and facing each other along the rotation axis AR.
- the third transmission / reception unit 340 connected to the transmission / reception of information included in the first circuit unit 311 and the fourth transmission / reception circuit connected to the information transmission / reception circuit included in the second circuit unit 315.
- the transmission / reception unit 341 can transmit / receive electromagnetic waves to and from each other. Therefore, for example, an electric signal including information from the first arm unit 101 is transmitted to the third transmission / reception unit 340 through the first connector unit 309 and the first circuit unit 311 (information transmission / reception circuit), and includes the information.
- the fourth transmission / reception unit 341 converts the received electromagnetic wave into an electric signal including information contained in the electromagnetic wave and outputs the signal.
- the electric signal including the information from the fourth transmission / reception unit 341 is transmitted to the second arm unit 102 through the second circuit unit 315 (information transmission / reception circuit) and the second connector unit 313. By such an operation, information can be wirelessly transmitted from the first arm portion 101 to the second arm portion 102.
- the information When transmitting information from the second arm unit 102 to the first arm unit 101, the information may be transmitted in the reverse order of the above.
- the electric signal including the information from the second arm unit 102 is transmitted to the fourth transmission / reception unit 341 through the second connector unit 313 and the second circuit unit 315 (information transmission / reception circuit), and the electromagnetic wave including the information is transmitted. Then, it is received by the third transmission / reception unit 340.
- the third transmission / reception unit 340 converts the received electromagnetic wave into an electric signal including information contained in the electromagnetic wave and outputs the signal.
- the electric signal including the information from the third transmission / reception unit 340 is transmitted to the first arm unit 101 through the first circuit unit 311 (information transmission / reception circuit) and the first connector unit 309.
- the transmission / reception units 340 and 341 are arranged in a state of being separated from each other and facing each other along the rotation axis AR, even when the first unit 106 and the second unit 107 rotate about the rotation axis AR, the radio is transmitted. To transmit information with.
- the wireless connector 300 can operate as described above regardless of the bending / stretching state and operation of the arm portions 101 and 102, so that information can be obtained between the first arm portion 101 and the second arm portion 102. Can be transmitted wirelessly.
- the wireless connector attachment / detachment method according to the present embodiment is a method for attaching / detaching the wireless connector 300 to / from the arm portions 101 and 102, and includes an attachment method and a removal method of the wireless connector 300.
- the attachment method and the removal method of the wireless connector 300 are the same as the attachment method and the removal method of the wireless connector 100 according to the first embodiment described above. That is, in the description of the wireless connector attachment / detachment method according to the first embodiment, the component of the wireless connector 100 according to the first embodiment may be replaced with the component of the wireless connector 300 according to the second embodiment corresponding to each. .. For the sake of brevity, detailed description of the method of attaching and detaching the wireless connector 300 will be omitted.
- the wireless connector 300 can be attached to and detached from the arm portions 101 and 102 by working outside the arm portions 101 and 102. Thereby, for example, the defective wireless connector 300 can be easily replaced with a normal wireless connector 300. Therefore, the wireless connector 300 can be easily repaired on the arm portions 101 and 102. In addition, the same effect as that of the first embodiment is obtained in the present embodiment as well.
- the transmission / reception units 310 and 314 are arranged substantially parallel to each other.
- the transmission / reception units 340, 341 are subjected to the bending / stretching state and the bending / stretching operation of the arm units 101, 102, similarly to the transmission / reception units 110, 114 according to the first embodiment.
- magnetic field coupling can be performed with a relatively stable strength in a predetermined range. Therefore, even when the wireless connector 300 is arranged outside the arm portions 101 and 102, stable wireless power and information transmission becomes possible.
- the present invention is not limited thereto.
- the present invention also includes a form in which a part or all of the embodiments and modifications described above are appropriately combined, and a form in which the form is appropriately modified.
Landscapes
- Engineering & Computer Science (AREA)
- Computer Networks & Wireless Communication (AREA)
- Power Engineering (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Manipulator (AREA)
- Details Of Connecting Devices For Male And Female Coupling (AREA)
Abstract
無線コネクタ100は、電力及び情報の少なくとも一方である伝送対象を無線で伝送するためのコネクタであって、第1対象物の外部から取り外し可能に取り付けられる第1ユニット106と、第2対象物の外部から取り外し可能に取り付けられる第2ユニット107とを備える。第1ユニット106は、伝送対象を無線で伝送するための第1送受信部110、第1対象物に取り付けられることによって第1対象物との間で伝送対象を伝送するための第1コネクタ部109が固定された第1ハウジング108を含む。第2ユニット107は、第1送受信部110との間で伝送対象を無線で伝送するための第2送受信部114、及び、第2対象物に取り付けられることによって第2対象物との間で伝送対象を伝送するための第2コネクタ部113が固定された第2ハウジングとを含む。第1送受信部110と第2送受信部114とは、伝送対象を無線で伝送するように互いに離間して対向した状態で配置される。
Description
本発明は、無線コネクタ着脱方法、ロボット装置及び無線コネクタに関する。
負荷に無線で電力を供給する技術が知られており、産業用ロボットなどに適用されている。例えば引用文献1には、図17(a)に示すように、ロボットアーム装置の関節部J2,J4のそれぞれに無線給電ユニットIHU2,IHU4を設ける例が開示されている。無線給電ユニットIHU2,IHU4は、一対のコイルを介して関節部J2,J4において電力を無線で伝送する。
無線給電ユニット100(無線給電ユニットIHU2に相当)は、図17(b)に示すように、送電装置10と受信装置20とを備える。送電装置10は、コイルなどを含む送電アンテナ11と、インバータ回路13、送電制御回路15とを備える。受信装置20は、コイルなどを含む受電アンテナ21と整流回路23とを備える。
一般的に、無線で電力を送受信するためのコイルは動作時に発熱することが多く、コイルの発熱に伴って無線給電ユニット100に不具合が生じることがある。無線給電ユニット100の不具合は、ロボットアーム装置の動作に支障をきたす場合があるので、無線給電ユニット100の交換などによって無線給電ユニット100を容易に修理できることが望ましい。
しかしながら、引用文献1では、一対のコイルの配置など無線給電ユニット100がどのように関節部J2,J4に設けられるかを開示していない。そのため、引用文献1を参照しても、容易に修理できる無線給電ユニット100を得ることは困難である。
本発明は、このような事情に鑑みてなされたものであって、容易に修理することが可能な無線コネクタの提供を目的とする。
上記目的を達成するため、本発明の第1の観点に係る無線コネクタ着脱方法は、
回転軸を支点にして回転可能に連結された第1対象物と第2対象物との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタを前記第1対象物及び前記第2対象物に着脱するための無線コネクタ着脱方法であって、
前記無線コネクタは、
前記伝送対象を無線で伝送するための第1送受信部、及び、前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部が固定された第1ハウジングと、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部、及び、前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部が固定された第2ハウジングとを備え、
前記第1対象物の外部から前記第1コネクタ部を前記第1対象物に取り付け、前記第2対象物の外部から前記第2コネクタ部を前記第2対象物に取り付けることによって、前記第1送受信部と前記第2送受信部とが前記伝送対象を無線で伝送するように互いに離間して対向した状態で前記第1対象物及び前記第2対象物に前記無線コネクタを取り付けることと、
前記第1対象物の外部での作業によって前記第1コネクタ部を前記第1対象物から取り外し、前記第2対象物の外部での作業によって前記第2コネクタ部を前記第2対象物から取り外すことによって、前記第1対象物及び前記第2対象物から前記無線コネクタを取り外すことを含む。
上記目的を達成するため、本発明の第2の観点に係るロボット装置は、
回転軸を支点にして回転可能に連結する関節機構を介して連結された第1アーム部及び第2アーム部と、
前記第1アーム部と前記第2アーム部との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタとを備え、
前記第1アーム部は、前記第1アーム部の外部に露出した第1相手コネクタ部を含み、
前記第2アーム部は、前記第2アーム部の外部に露出した第2相手コネクタ部を含み、
前記無線コネクタは、
前記伝送対象を無線で伝送するための第1送受信部、及び、前記第1相手コネクタに取り外し可能に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部が固定された第1ハウジングと、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部、及び、前記第2相手コネクタに取り外し可能に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部が固定された第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1コネクタ部と前記第2コネクタ部とがそれぞれ前記第1相手コネクタ部と前記第2相手コネクタ部とに取り付けられた場合に、前記関節機構の外部で前記伝送対象を無線で伝送するように前記回転軸に沿って互いに離間して対向した状態で配置される。
上記目的を達成するため、本発明の第3の観点に係る無線コネクタは、
第1対象物と第2対象物との間で、電力である第1伝送対象を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記第1伝送対象を無線で伝送するための第1送受信部と、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記第1伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部と前記第1コネクタ部とが固定された第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記第1伝送対象を無線で伝送するための第2送受信部と、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記第1伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部と前記第2コネクタ部とが固定された第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第1伝送対象を無線で伝送するように互いに離間して対向した状態で配置される。
前記第1送受信部は、前記第1伝送対象を伝送するための平板状の第1コイル部材を含み、
前記第2送受信部は、前記第1コイル部材と磁界結合することによって前記第1伝送対象を伝送するための平板状の第2コイル部材を含み、
前記第1コイル部材と前記第2コイル部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第1伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置されてもよい。
前記第2送受信部は、前記第1コイル部材と磁界結合することによって前記第1伝送対象を伝送するための平板状の第2コイル部材を含み、
前記第1コイル部材と前記第2コイル部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第1伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置されてもよい。
前記第1ユニットは、
前記第1ハウジングに固定されており、情報である第2伝送対象を無線で伝送するための第3送受信部をさらに含み、
前記第2ユニットは、
前記第2ハウジングに固定されており、前記第3送受信部との間で前記第2伝送対象を無線で伝送するための第4送受信部をさらに含み、
前記第1コネクタ部は、前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記第1伝送対象及び前記第2伝送対象を伝送し、
前記第2コネクタ部は、前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記第1伝送対象及び前記第2伝送対象を伝送し、
前記第3送受信部と前記第4送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第2伝送対象を無線で伝送するように互いに離間して対向した状態で配置されてもよい。
前記第3送受信部は、情報である前記第2伝送対象を伝送するための第1アンテナ部材を含み、
前記第4送受信部は、前記第2伝送対象を伝送するための第2アンテナ部材を含み、
前記第1送受信部は、前記第3送受信部の周囲に設けられ
前記第2送受信部は、前記第4送受信部の周囲に設けられ、
前記第1アンテナ部材と前記第2アンテナ部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第2伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置されてもよい。
前記第4送受信部は、前記第2伝送対象を伝送するための第2アンテナ部材を含み、
前記第1送受信部は、前記第3送受信部の周囲に設けられ
前記第2送受信部は、前記第4送受信部の周囲に設けられ、
前記第1アンテナ部材と前記第2アンテナ部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第2伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置されてもよい。
上記目的を達成するため、本発明の第4の観点に係る無線コネクタは、
第1対象物と第2対象物との間で、伝送対象である電力及び情報の少なくとも一方を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1コイル部材を含む第1送受信部と、
前記第1対象物の外部から前記第1対象物に嵌め合わされることによって、前記第1対象物との間で前記伝送対象を伝送するように前記第1対象物に取り外し可能に取り付けられる第1コネクタ部と、
前記第1コイル部材と前記第1コネクタ部とが固定される第1ハウジングとを含み、
前記第2ユニットは、
前記第1コイル部材との間で前記伝送対象を無線で伝送するための第2コイル部材を含む第2送受信部と、
前記第2対象物の外部から前記第2対象物に嵌め合わされることによって、前記第2対象物との間で前記伝送対象を伝送するように前記第2対象物に取り外し可能に取り付けられる第2コネクタ部と、
前記第2コイル部材と前記第2コネクタ部とが固定される第2ハウジングとを含み、
前記第1コネクタ部と前記第2コネクタ部とは、嵌合方向が同じ方向であり、
前記第1コイル部材と前記第2コイル部材とは、前記嵌合方向に沿って互いに離間して対向した状態で配置されることによって磁界結合する。
前記第1コイル部材は、第1の中心軸の周りに配置されており、
前記第2コイル部材は、第2の中心軸の周りに配置されており、
前記第1の中心軸と前記第2の中心軸とは、前記嵌合方向と平行であってもよい。
前記第2コイル部材は、第2の中心軸の周りに配置されており、
前記第1の中心軸と前記第2の中心軸とは、前記嵌合方向と平行であってもよい。
上記目的を達成するため、本発明の第5の観点に係る無線コネクタは、
第1対象物と第2対象物との間で、伝送対象である電力及び情報の少なくとも一方を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1コイル部材を含む第1送受信部と、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部と前記第1コネクタ部とが固定される第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2コイル部材を含む第2送受信部と、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部と前記第2コネクタ部とが固定される第2ハウジングとを含み、
前記第1コイル部材と前記第2コイル部材とは、互いに磁界結合する状態では、互いに離間して対向している。
上記目的を達成するため、本発明の第6の観点に係る無線コネクタは、
第1対象物と第2対象物との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタであって、
第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1送受信部と、
前記第1対象物に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部が固定され、前記第1コネクタ部が取り付けられる第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部と、
前記第2対象物に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部が固定され、前記第2コネクタ部が取り付けられる第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記伝送対象を無線で伝送するように互いに離間した状態で対向して配置される。
前記第1対象物と前記第2対象物とは、回転軸を支点にして回転可能に連結されていてもよい。
前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記回転軸に沿って互いに離間した状態で対向して配置されてもよい。
前記第1ユニットと前記第2ユニットとは、前記第1対象物及び前記第2対象物のそれぞれに取り付けられた場合に、互いに離間していてもよい。
前記第1ユニットと前記第2ユニットとは、前記第1対象物及び前記第2対象物のそれぞれに取り付けられた場合に、前記第1送受信部と前記第2送受信部との相対的な位置関係を予め定められた範囲に制限するガイド機構をさらに含んでもよい。
本発明によれば、無線コネクタを容易に修復することが可能になる。
以下、本発明の実施の形態に係る無線コネクタついて、図面を参照しつつ説明する。全図を通じて同一の要素には同一の符号を付す。
<<実施の形態1>>
(実施の形態1に係る無線コネクタ100の構成)
本発明の実施の形態1に係る無線コネクタ100は、図1の斜視図、図2の平面図、図3の分解斜視図に示すように、第1アーム部101と第2アーム部102との間で電力を無線で伝送するためのコネクタである。無線コネクタ100は、第1アーム部101と第2アーム部102との外部に着脱可能に取り付けられる。本実施の形態では、磁界結合(詳細には、電磁誘導)により無線で電力を伝送する例を説明する。
(実施の形態1に係る無線コネクタ100の構成)
本発明の実施の形態1に係る無線コネクタ100は、図1の斜視図、図2の平面図、図3の分解斜視図に示すように、第1アーム部101と第2アーム部102との間で電力を無線で伝送するためのコネクタである。無線コネクタ100は、第1アーム部101と第2アーム部102との外部に着脱可能に取り付けられる。本実施の形態では、磁界結合(詳細には、電磁誘導)により無線で電力を伝送する例を説明する。
アーム部101,102は、産業用ロボット、人型ロボットなどのロボット装置において関節機構103を介して連結される。ここで、「アーム部101,102」は、第1アーム部101と第2アーム部102との総称であり、以下においても同様である。なお、アーム部101,102は、外殻OS1,OS2のそれぞれによって覆われており、これらの内部の機構や配線は露出していない。
関節機構103は、回転軸ARを支点にして回転可能に第1アーム部101と第2アーム部102とを連結する機構である。これにより、第1アーム部101と第2アーム部102とは、屈伸可能に連結される。
本実施の形態に係る関節機構103は、例えば、第2アーム部102に固定される軸部103Aと、第1アーム部101に設けられる孔部103Bとが互いに嵌り合うことで構成される。関節機構103は、軸部103Aの軸心を回転軸ARとして回転可能にアーム部101,102を連結する。
第1アーム部101と第2アーム部102とは、いずれが電源側であってもよいが、本実施の形態では、第1アーム部101が電源側であり、第2アーム部102が負荷側である例によって説明する。
例えば、第1アーム部101及び第2アーム部102が産業用ロボットに含まれる場合、関節機構103とは反対側の第1アーム部101の端部(図示せず)には、他の部材(他のアーム部、基台など)が接続される。また、関節機構103とは反対側の第2アーム部102の端部(図示せず)には、他の部材(他のアーム部、部品を挟み持つためのハンド部など)が接続される。
この場合の負荷は、例えば、第2アーム部102及びこれに接続される他の部材に搭載されるアクチュエータ、制御回路などであり、第1アーム部101と第2アーム部102とを回転させるために関節機構103に設けられるモータを含んでもよい。
以下の説明では、電気コネクタ100が取り付けられたアーム部101,102が真っ直ぐに伸びた状態で規定した上・下・前・後・右・左の方向を示す用語を用いる。
詳細には、回転軸ARに沿う方向を前後方向として規定し、アーム部101,102に沿う方向を左右方向とする。また、無線コネクタ100において電力を無線で伝送するために互いに対置される部位(後述する第1送受信部110及び第2送受信部114)が、アーム部101,102に対して位置する方向を前方とし、その反対方向を後方とする。上・下・左・右の各方向は、前方から見た方向に従って規定する。
ただし、これらの方向を示す用語は、説明のために用いるのであって、本発明を限定する趣旨ではない。
第1アーム部101と第2アーム部102とは、それぞれ、第1相手コネクタ部104と第2相手コネクタ部105とを含む。第1相手コネクタ部104と第2相手コネクタ部105との各々は、無線コネクタ100との間で電力を伝送するためのコネクタであり、第1アーム部101と第2アーム部102とのそれぞれに外部に露出して設けられる。
本実施の形態に係る第1相手コネクタ部104と第2相手コネクタ部105との各々は、上下方向に間隔を開けて並べられた複数の電気接点を含むオス側の電気コネクタである。
詳細には、第1相手コネクタ部104は、回転軸ARの右方に設けられ、第1アーム部101の外殻OS1の前面から前方に突き出す。第2相手コネクタ部105は、回転軸ARの左方に設けられ、第2アーム部102の外殻OS2の前面から前方に突き出す。
図1~3に示すように、無線コネクタ100は、第1アーム部101と第2アーム部102とのそれぞれに外部から着脱可能に取り付けられる第1ユニット106と第2ユニット107とを備える。
本実施の形態に係る第1ユニット106と第2ユニット107とは、互いに接触することなく離間している。そのため、第1ユニット106と第2ユニット107とは、第1アーム部101と第2アーム部102とのそれぞれに取り付けられると、回転軸ARを中心として相対的に回転することができる。
図1~3及び後方から見た図4に示すように、第1ユニット106は、第1ハウジング108と、第1コネクタ部109と、第1送受信部110と、第1回路部111とを含む。なお、図4では、後述する第1ボルト128を図示省略している。
図1~3及び図5に示すように、第2ユニット107は、第1ユニット106に含まれる構成要素108~111のそれぞれに対応する構成要素112~115を含む。詳細には、第2ユニット107は、第2ハウジング112と、第2コネクタ部113と、第2送受信部114と、第2回路部115とを含む。なお、図5(a)及び(b)は、第2ユニット107を前方及び後方のそれぞれから見た図であって、これらでは後述する第2ボルト129を図示省略している。
第1ハウジング108と第2ハウジング112とは、第1ユニット106と第2ユニット107とのそれぞれに含まれる他の構成要素109~111,113~115が取り付けられる部材であって、典型的には中空の樹脂製である。
本実施の形態に係る第1ハウジング108は、第1アーム部101に取り付けるための第1アーム取付部120と、第1対置部121とを含む。第2ハウジング112は、第2アーム部102に取り付けるための第2アーム取付部122と、第1対置部121と互いに回転軸ARに沿って離間して対向した状態で配置される第2対置部123とを含む。
第1アーム取付部120と第2アーム取付部122との各々は、概ね直方体状の外形をなす。第1アーム取付部120と第2アーム取付部122とは、前後方向の長さを除いて概ね同じ大きさであって、前後方向の長さは第1アーム取付部120の方が第2アーム取付部122よりも長い。
詳細には、第1アーム取付部120は、第1開口124と4つの第1ボルト孔125とを含む。また、第2アーム取付部122は、第2開口126と4つの第2ボルト孔127とを含む。
第1開口124と第2開口126とは、第1アーム取付部120と第2アーム取付部122とのそれぞれの内部の空間を外部に接続するように後方の壁部に設けられる。第1開口124の内方(前方)と第2開口126の内方(前方)とには、それぞれ、詳細後述する第1コネクタ部109と第2コネクタ部113とが設けられる。
第1ボルト孔125と第2ボルト孔127との各々は、前後方向の貫通孔である。第1ボルト孔125には、第1ハウジング108を第1アーム部101に固定するための第1ボルト128が貫通した状態で配置される。第2ボルト孔127には、第2ハウジング112を第2アーム部102に固定するための第2ボルト129が貫通した状態で配置される。
第1対置部121と第2対置部123とは、それぞれの基端が第1アーム取付部120の左端と第2アーム取付部122の右端とに接続し、互いに近接する方向に延びる平板状の部位である。これによって、第1対置部121と第2対置部123とは、回転軸ARに沿って互いに離間して対向する。
詳細には、第1対置部121は、第1アーム取付部120の左端に基端が接続し、当該基端から前面を第1アーム取付部120の前面と面一にして左方へ延びる。第1対置部121は、第1アーム取付部120の高さと概ね同じ一定の高さで基端から延び、先端が前方から見て左方へ突き出た半円状をなす。ここで、「高さ」は、上下方向の長さであり、以下においても同様である。
第2対置部123は、第2アーム取付部122の右端に基端が接続し、当該基端から前面を第2アーム取付部122の前面と面一にして右方へ延びる。第2対置部123は、第2アーム取付部122の高さと概ね同じ一定の高さで基端から延び、先端が前方から見て右方へ突き出た半円状をなす。
第1対置部121の厚さは、第1アーム取付部120と第2アーム取付部122との厚さの差よりも薄い。これにより、第1対置部121の先端は第2対置部123の前方に間隔を空けて配置される。そして、第1対置部121と第2対置部123とは、各々の先端を含む概ね円形の領域が関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で配置される。第2対置部123の厚さは、適宜設定されてよいが、第2アーム取付部122よりも薄く、本実施の形態では第1対置部121の厚さと概ね同じである。ここで、「厚さ」は、前後方向の長さであり、以下においても同様である。
第1コネクタ部109は、第1アーム部101との間で電力を伝送するための部位である。第1コネクタ部109は、第1アーム部101の外部から第1アーム部101に取り外し可能に取り付けられる。第1コネクタ部109は、第1相手コネクタ部104に取り付けられることによって、第1アーム部101との間で電力を伝送する。
本実施の形態に係る第1コネクタ部109は、第1ハウジング108に固定されたメス側の電気コネクタであり、第1開口124の前方にて上下方向に間隔を開けて並べられた複数の電気接点を含む。これにより、第1コネクタ部109は、第1開口124を通じて第1ハウジング108の外部に露出するので、第1ハウジング108の後方から第1開口124を通じて差し込まれた第1相手コネクタ部104と前後方向に互いに嵌り合う。互いに嵌り合った第1コネクタ部109と第1相手コネクタ部104とは、それぞれの電気接点が接触することによって互いに電気的に接続し、電力を伝送することができる。
なお、第1コネクタ部109と第1相手コネクタ部104とのメス側とオス側との関係は、入れ替えられてもよい。第1相手コネクタ部104は、メス側である場合も第1アーム部101の外部に露出していればよく、これによって、第1アーム部101の外部から第1コネクタ部109を取り外し可能に取り付けることができる。具体的には例えば、第1アーム部101の外殻OS1に開口を設け、第1相手コネクタ部104を構成する電気接点が当該開口の内方に設けられればよい。
第2コネクタ部113は、第2アーム部102との間で電力を伝送するための部位である。第2コネクタ部113は、第2アーム部102の外部から第2アーム部102に取り外し可能に取り付けられる。第2コネクタ部113は、第2相手コネクタ部105に取り付けられることによって、第2アーム部102との間で電力を伝送する。
本実施の形態に係る第2コネクタ部113は、第2ハウジング112に固定されたメス側の電気コネクタであり、第2開口126の前方にて上下方向に間隔を開けて並べられた複数の電気接点を含む。これにより、第2コネクタ部113は、第2開口126を通じて第2ハウジング112の外部に露出するので、第2ハウジング112の後方から第2開口126を通じて差し込まれた第2相手コネクタ部105と前後方向に互いに嵌り合う。互いに嵌り合った第2コネクタ部113と第2相手コネクタ部105とは、それぞれの電気接点が接触することによって互いに電気的に接続し、電力を伝送することができる。
なお、第2コネクタ部113と第2相手コネクタ部105とのメス側とオス側との関係は、入れ替えられてもよい。第2相手コネクタ部105は、メス側である場合も第2アーム部102の外部に露出していればよく、これによって、第2アーム部102の外部から第2コネクタ部113を取り外し可能に取り付けることができる。具体的には例えば、第2アーム部102の外殻OS2に開口を設け、第2相手コネクタ部105を構成する電気接点が当該開口の内方に設けられればよい。
第1送受信部110と第2送受信部114とは、これらの間で電力を無線で伝送するための部材であって、電力を無線で伝送するように関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で配置される。典型的には、第1送受信部110と第2送受信部114とは、それぞれ、第1の中心軸C1と第2の中心軸C2とを中心とする形状であり、例えば円板状である。
本実施の形態では、第1送受信部110は、その外縁が第1対置部121の先端と概ね一致するように、第1対置部121の後方の外面に例えば接着剤、ビスなどで固定される。第2送受信部114は、その外縁が第2対置部123の先端と概ね一致するように、第2対置部123の前方の外面に例えば接着剤、ビスなどで固定される。
これにより、第1送受信部110と第2送受信部114とは、第1対置部121と第2対置部123とのそれぞれの回転軸ARに沿って互いに対向する領域に固定される。従って、第1送受信部110と第2送受信部114とは、関節機構103の外部で回転軸ARに沿って互いに対向して配置される。また、第1送受信部110と第2送受信部114とは、互いに接触することなく離間した状態で配置され、好ましくは、回転軸ARに対して垂直な方向を向けて互いに平行に配置される。
本実施の形態に係る第1送受信部110と第2送受信部114とは、それぞれ、概ね同じ大きさの円板状の第1コイル部材と第2コイル部材である。すなわち、第1コイル部材は、第1の中心軸C1を中心とする円板状である。第2コイル部材は、第2の中心軸C2を中心とする円板状である。
第1コイル部材と第2コイル部材との各々は、例えば、中心軸C1又はC2の周りに渦巻き状に巻き回された導線、中心軸C1又はC2の周りに渦巻き状に基板に印刷されたプリント配線などによって構成されるとよい。
第1コイル部材と第2コイル部材とは、回転軸ARに沿って互いに対向した状態で配置されるので、電磁誘導によって磁界結合する。これにより、第1コイル部材と第2コイル部材との間で電力を無線で伝送することができる。
ここで、第1送受信部110と第2送受信部114とは、これらの間の結合(本実施の形態では、磁界結合)を強くするには、互いに対向する領域の面積(対向面積)は大きい方が望ましく、3つの軸AR,C1,C2は、一致することが望ましい。しかし、第1送受信部110と第2送受信部114とは、電力を伝送するように(本実施の形態では、磁界結合するように)回転軸ARに沿って互いに対向した状態で配置されればよく、3つの軸AR,C1,C2が製造誤差、設計上の制約などによってズレていてもよい。
また、本実施の形態では、第1送受信部110の前方と第2送受信部114の後方とのそれぞれには、金属、軟磁性体などで作られたシート状のシールド部材S1,S2が設けられている。これにより、第1送受信部110と第2送受信部114とが回転軸ARに沿ってシールド部材S1,S2に挟まれるので、外部へ放出される電磁波などを抑制することができる。
なお、第1送受信部110は、第1コイル部材に直列又は並列に接続されるコンデンサなどをさらに含んでもよく、第1コイル部材などが収容される樹脂製のケースをさらに含んでもよい。第2送受信部114も同様に、第2コイル部材に直列又は並列に接続されるコンデンサなどをさらに含んでもよく、第2コイル部材などが収容される樹脂製のケースをさらに含んでもよい。
第1回路部111は、第1コネクタ部109と第1送受信部110とに電気的に接続される電気回路である。第1回路部111は、第1コネクタ部109と第1送受信部110との各々と互いに電気的に接続した状態で第1ハウジング108の内部に固定されている。
本実施の形態では、第1回路部111は、第1コネクタ部109の前端に固定されており、第1送受信部110とは第1導線130を介して互いに電気的に接続している。
また本実施の形態では、上述の通り、第1アーム部101が電源側である。そのため、第1回路部111は、送電回路であり、例えば、第1アーム部101から第1コネクタ部109を通じて供給された電力を第1送受信部110へ出力するための電力に変換するインバータ回路などを含む。
第2回路部115は、第2コネクタ部113と第2送受信部114とに電気的に接続される電気回路である。第2回路部115は、第2コネクタ部113と第2送受信部114との各々と互いに電気的に接続した状態で第2ハウジング112の内部に固定されている。
本実施の形態では、第2回路部115は、第2コネクタ部113の前端に固定されており、第2送受信部114とは第1導線131を介して互いに電気的に接続している。
また本実施の形態では、上述の通り、第2アーム部102が負荷側である。そのため、第2回路部115は、受電回路であり、例えば、第1送受信部110と磁界結合した第2送受信部114によって受信された電力を第2コネクタ部113を通じて第2アーム部102へ出力するための電力に変換する整流・平滑回路を含む。
これまで、本発明の実施の形態1に係る無線コネクタ100の構成について説明した。
一般的に、第1ユニット106と第2ユニット107とは、製造誤差などによって、アーム部101,102に取り付けられた場合に、設計上の回転軸(例えば、第1の中心軸C1と第2の中心軸C2とに一致する軸)が回転軸ARに一致しない可能性がある。本実施の形態に係る第1ユニット106と第2ユニット107とは、上述の通り互いに接触することなく離間している。そのため、設計上の回転軸が回転軸ARからズレていても、アーム部101,102の屈曲に伴って回転軸ARを中心に回転することができる。
また、第1ユニット106と第2ユニット107とは、互いに接触することなく離間している。そのため、相対的に回転しても摩耗することが殆どなく、電気コネクタ100の耐久性を向上させることが可能になる。
(実施の形態1に係る無線コネクタ100の動作)
ここから、本実施の形態に係る無線コネクタ100の動作について、図6の回路構成図を参照して説明する。
ここから、本実施の形態に係る無線コネクタ100の動作について、図6の回路構成図を参照して説明する。
第1アーム部101(電源側)から供給された電力は、図6に示すように、第1コネクタ部109と第1回路部111とを通じて第1送受信部110に供給される。これにより、第1送受信部110に交流電流が流れて、第1送受信部110の周囲に磁界が生じる。
第1送受信部110と第2送受信部114とは、上述したように、回転軸ARに沿って互いに離間して対向した状態で配置される。そのため、第1送受信部110と第2送受信部114とは磁界結合し、第1送受信部110の周囲に発生した磁界に応じた誘導起電力が第2送受信部114に発生する。すなわち、本実施の形態では、第1送受信部110を構成する第1コイル部材が送電コイルとして機能し、第2送受信部114を構成する第2コイル部材が受電コイルとして機能する。
第2送受信部114に発生した電力は、第2回路部115と第2コネクタ部113とを通じて、第2アーム部102(負荷側)へ供給される。このように、無線コネクタ100によって、第1アーム部101と第2アーム部102との間で電力を無線で伝送することができる。
本実施の形態では、上述の通り、アーム部101,102が回転軸ARを支点として回転することで屈伸し、これに伴って、第1ユニット106と第2ユニット107とは回転軸ARを中心に回転する。
送受信部110,114は、回転軸ARに沿って互いに離間して対向した状態で配置されるので、第1ユニット106と第2ユニット107とが回転した場合においても、電磁誘導によって磁界結合する。そのため、アーム部101,102の屈伸の状態に関わらず、またアーム部101,102が屈伸の動作中であっても、無線コネクタ100は、上述した動作と同様に動作することができるので、第1アーム部101と第2アーム部102との間で電力を無線で伝送することができる。ここで、「送受信部110,114」は、第1送受信部110と第2送受信部114との総称であり、以下においても同様である。
好ましくは、送受信部110,114は、相対的な位置関係を制限した状態で配置される。すなわち、送受信部110,114は、回転軸ARを中心として回転した場合においても、これらの相対的な位置関係が予め定められた範囲となるように配置される。
ここで、送受信部110,114の相対的な位置関係とは、送受信部110,114が回転軸ARに沿って離間する距離(離間距離)、互いに対向する領域の面積(対向面積)、回転軸ARに対してなす角度などである。実施の形態において送受信部110,114が互いに平行に配置されることは、相対的な位置関係を制限した状態で配置されることの一例である。
送受信部110,114の相対的な位置関係を制限することによって、送受信部110,114は、アーム部101,102の屈伸状態及び屈伸動作に関わらず、予め定められた範囲の比較的安定した強さで磁界結合することができる。従って、アーム部101,102の外部に無線コネクタ100を配置した場合であっても、無線での安定した電力の伝送が可能になる。
(実施の形態1に係る無線コネクタ着脱方法)
これまで、本発明の実施の形態1に係る無線コネクタ100の動作について説明した。ここから、本実施の形態に係る無線コネクタ着脱方法について、図7~8を参照して説明する。
これまで、本発明の実施の形態1に係る無線コネクタ100の動作について説明した。ここから、本実施の形態に係る無線コネクタ着脱方法について、図7~8を参照して説明する。
本実施の形態に係る無線コネクタ着脱方法は、無線コネクタ100をアーム部101,102に着脱するための方法であって、無線コネクタ100の取り付け方法と取り外し方法とを含む。
(無線コネクタ100の取り付け方法)
図7は、無線コネクタ100の取り付け方法の流れを示すフローチャートである。無線コネクタ100の取り付け方法は、関節機構103を介して連結されたアーム部101,102を含むロボット装置と、無線コネクタ100とを準備して開始される。
図7は、無線コネクタ100の取り付け方法の流れを示すフローチャートである。無線コネクタ100の取り付け方法は、関節機構103を介して連結されたアーム部101,102を含むロボット装置と、無線コネクタ100とを準備して開始される。
図7に示すように、第2ユニット107が第2アーム部102の外部から第2アーム部102に取り付けられる(工程1;第2ユニットの取り付け工程)。
詳細には、工程1において、第2送受信部114が回転軸AR上で関節機構103の前方に位置付けられた状態で、第2コネクタ部113が、第2アーム部102に取り付けられる(工程1A;第2コネクタ部の取り付け工程)。
本実施の形態では、第2相手コネクタ部105を嵌め込むことによって、第2コネクタ部113は、第2アーム部102に取り付けられる。第2相手コネクタ部105は第2アーム部102の外部に露出しているので、第2コネクタ部113は、第2アーム部102の外部から第2アーム部102に取り付けられる。
このように第2コネクタ部113が取り付けられることによって、第2コネクタ部113と第2相手コネクタ部105とが電気的に接続する。また本実施の形態では、第2コネクタ部113が第2ハウジング112に固定されているので、第2ハウジング112は、第2コネクタ部113とともに第2アーム部102に取り付けられる。これにより、第2ユニット107が第2アーム部102に取り付けられる。
図7に示すように、第2ユニット107が第2アーム部102に固定される(工程1B;固定工程)。
本実施の形態では、第2ボルト129を第2ボルト孔127の各々に挿入して、第2アーム部102に設けられた第2ボルト穴部132にネジ作用で嵌めることによって、第2ハウジング112が第2アーム部102に固定される。なお、第2ユニット107を第2アーム部102に固定する方法は、ボルト止めに限られず、例えば爪と第2開口126の周辺部との引っ掛かりによる係止などであってもよい。
図7に示すように、第1ユニット106が第1アーム部101の外部から第1アーム部101に取り付けられる(工程2;第1ユニットの取り付け工程)。
詳細には、工程2において、第1送受信部110が回転軸AR上で関節機構103及び第2送受信部114の前方に位置付けられた状態で、第1コネクタ部109が、第1アーム部101に取り付けられる(工程2A;第1コネクタ部の取り付け工程)。
本実施の形態では、第1相手コネクタ部104を嵌め込むことによって、第1コネクタ部109は、第1アーム部101に取り付けられる。第1相手コネクタ部104は第1アーム部101の外部に露出しているので、第1コネクタ部109は、第1アーム部101の外部から第1アーム部101に取り付けられる。
このように第1コネクタ部109が取り付けられることによって、第1コネクタ部109と第1相手コネクタ部104とが電気的に接続する。また本実施の形態では、第1コネクタ部109が第1ハウジング108に固定されているので、第1ハウジング108は、第1コネクタ部109とともに第1アーム部101に取り付けられる。これにより、第1ユニット106が第1アーム部101に取り付けられる。
図7に示すように、第1ユニット106が第1アーム部101に固定される(工程2B;固定工程)。
本実施の形態では、第1ボルト128を第1ボルト孔125の各々に挿入して、第1アーム部101に設けられた第1ボルト穴部133にネジ作用で嵌めることによって、第1ハウジング108が第1アーム部101に固定される。なお、第1ユニット106を第1アーム部101に固定する方法は、ボルト止めに限られず、例えば爪と第1開口124の周辺部との引っ掛かりによる係止などであってもよい。
これにより、無線コネクタ100の取り付け方法が終了し、電気コネクタ100は、第1アーム部101及び第2アーム部102に固定した状態で取り付けられる。また、送受信部110,114は、電力を無線で伝送するように関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で、回転軸ARに対して概ね垂直な方向を向いて概ね平行に配置される。
(無線コネクタ100の取り外し方法)
図8は、無線コネクタ100の取り外し方法の流れを示すフローチャートである。無線コネクタ100の取り外し方法は、典型的には、上述した無線コネクタ100の取り付け方法によって無線コネクタ100をロボット装置に取り付けた後に、必要に応じて行われる。無線コネクタ100の取り外しが必要な場合の例としては、不具合が生じた無線コネクタ100を修理するために、正常な無線コネクタ100に交換する場合などを挙げることができる。
図8は、無線コネクタ100の取り外し方法の流れを示すフローチャートである。無線コネクタ100の取り外し方法は、典型的には、上述した無線コネクタ100の取り付け方法によって無線コネクタ100をロボット装置に取り付けた後に、必要に応じて行われる。無線コネクタ100の取り外しが必要な場合の例としては、不具合が生じた無線コネクタ100を修理するために、正常な無線コネクタ100に交換する場合などを挙げることができる。
図8に示すように、第1ユニット106が第1アーム部101の外部での作業によって第1アーム部101から取り外される(工程3;第1ユニットの取り外し工程)。
詳細には、図8に示すように、第1ユニット106と第1アーム部101との固定が解かれる(工程3A;固定の解除工程)。本実施の形態では、第1ボルト128と第1ボルト穴部133とのネジ作用による嵌り合いを解いた後に、第1ボルト128が第1ボルト孔125から取り外される。
図8に示すように、第1コネクタ部109が第1アーム部101から取り外される(工程3B;第1コネクタ部の取り外し工程)。
本実施の形態では、例えば第1アーム部101の外部で作業者が手や治具などを用いて第1ハウジング108を把持する。そして、第1コネクタ部109を第1相手コネクタ部104から引く抜くことで、第1コネクタ部109が第1アーム部101から取り外される。
本実施の形態では第1コネクタ部109が第1ハウジング108に固定されているので、第1ハウジング108は、第1コネクタ部109とともに第1アーム部101から取り外される。これにより、第1ユニット106が、第1アーム部101から取り外される。
図8に示すように、第2ユニット107が第2アーム部102の外部での作業によって第2アーム部102から取り外される(工程4;第2ユニットの取り外し工程)。
詳細には、図8に示すように、第2ユニット107と第2アーム部102との固定が解かれる(工程4A;固定の解除工程)。本実施の形態では、第2ボルト129と第2ボルト穴部132とのネジ作用による嵌り合いを解いた後に、第2ボルト129が第2ボルト孔127から取り外される。
図8に示すように、第2コネクタ部113が第2アーム部102から取り外される(工程4B;第2コネクタ部の取り外し工程)。
本実施の形態では、例えば第2アーム部102の外部で作業者が手や治具などを用いて第2ハウジング112を把持する。そして、第2コネクタ部113を第2相手コネクタ部105から引く抜くことで、第2コネクタ部113が第2アーム部102から取り外される。
本実施の形態では第2コネクタ部113が第2ハウジング112に固定されているので、第2ハウジング112は、第2コネクタ部113とともに第1アーム部101から取り外される。これにより、第2ユニット107が、第2アーム部102から取り外される。
無線コネクタ100の取り外し方法が終了し、無線コネクタ100がアーム部101,102から取り外される。
これまで、本発明の実施の形態1について説明した。
本実施の形態によれば、アーム部101,102の外部での作業によって無線コネクタ100をアーム部101,102に着脱することができる。これにより、例えば、不具合が生じた無線コネクタ100を正常な無線コネクタ100に容易に交換することができる。従って、無線コネクタ100を容易に修理することが可能になる。
また、無線コネクタ100は、アーム部101,102の外部に配置された状態でアーム部101,102に取り付けられる。そのため、アーム部101,102の内部に設けられる場合よりも、アーム部101,102の内部の設計への影響が少なくなる。従って、アーム部101,102の設計の自由度を向上させることが可能になる。
また本実施の形態では、第1コネクタ部109と第1相手コネクタ部104との嵌合方向と、第2コネクタ部113と第2相手コネクタ部105との嵌合方向とは、いずれも同じ前後方向である。そして、送受信部110,114は、当該嵌合方向に沿って互いに離間して対向した状態で配置されることによって磁界結合する。
この場合、アーム部101,102においては、関節機構103の回転軸ARを介して互いに反対の方向に第1相手コネクタ部104及び第2相手コネクタ部105を設ければよい。そのため、第1相手コネクタ部104及び第2相手コネクタ部105を容易に設けることができる。また、無線コネクタ100においては、上述の構成の説明から分かるように、第1ユニット106及び第2ユニット107の構成を比較的簡易にすることができる。
従って、無線コネクタ100を簡易な構成として、アーム部101,102に容易に設けることが可能になる。
さらに本実施の形態によれば、第1の中心軸C1と第2の中心軸C2とは、平行な前後方向を向いており、第1コネクタ部109及び第2コネクタ部113の嵌合方向と平行である。これにより、簡易な構成で、第1送受信部110(第1コイル部材)と第2コネクタ部113(第2コイル部材)とを概ね互いに平行に配置して、良好に磁界結合させることができる。従って、簡易な構成で、かつ、良好に無線で電力を伝送することが可能になる。
これまで、本発明の実施の形態1について説明した。本発明は、本実施の形態に限定されるものではなく、実施の形態1を次のように変形した形態も含む。
<変形例1>
実施の形態1では、第1コネクタ部109と第2コネクタ部113とがそれぞれ第1ハウジング108と第2ハウジング112とに固定されている例を説明した。しかし、第1コネクタ部109と第2コネクタ部113とは、それぞれ、第1ハウジング108と第2ハウジング112とに固定されずに取り付けられていてもよい。
実施の形態1では、第1コネクタ部109と第2コネクタ部113とがそれぞれ第1ハウジング108と第2ハウジング112とに固定されている例を説明した。しかし、第1コネクタ部109と第2コネクタ部113とは、それぞれ、第1ハウジング108と第2ハウジング112とに固定されずに取り付けられていてもよい。
変形例1に係る無線コネクタ200は、図9に示すように、実施の形態1と同様に互いに接触することなく離間した第1ユニット206と第2ユニット207とを備える。
第1ユニット206は、実施の形態1と同様の第1送受信部110及び第1回路部111と、実施の形態1とは異なる第1コネクタ部209及び第1ハウジング208とを含む。
第1コネクタ部209は、実施の形態1と同様に、第1アーム部101との間で電力を伝送するための部位であって、互いに嵌り合うことで取り外し可能に第1相手コネクタ部104に取り付けられる電気コネクタである。第1コネクタ部209は、第1ハウジング208の外部へ延びる第1導線230を含み、第1ハウジング208の内部に設けられた第1回路部111に第1導線230を通じて接続している。
第1ハウジング208は、実施の形態1と同様の第1送受信部110が固定される第1対置部121と、実施の形態1とは異なる第1アーム取付部220とを含む。
第1アーム取付部220は、第1コネクタ部109が内部に設けられていない点を除いて、実施の形態1に係る第1アーム取付部120と概ね同様に構成されるとよい。
第2ユニット207は、実施の形態1と同様の第2送受信部114及び第2回路部115と、実施の形態1とは異なる第2コネクタ部213及び第2ハウジング212とを含む。
第2コネクタ部213は、実施の形態1と同様に、第2アーム部102との間で電力を伝送するための部位であって、互いに嵌り合うことで取り外し可能に第2相手コネクタ部105に取り付けられる電気コネクタである。第2コネクタ部213は、第2ハウジング212の外部へ延びる第1導線231を含み、第2ハウジング212の内部に設けられた第2回路部115に第1導線231を通じて接続している。
第2ハウジング212は、実施の形態1と同様の第2送受信部114が固定される第2対置部123と、実施の形態1とは異なる第2アーム取付部222とを含む。
第2アーム取付部222は、第2コネクタ部113が内部に設けられていない点を除いて、実施の形態1に係る第2アーム取付部122と概ね同様に構成されるとよい。
本変形例によっても、無線コネクタ200をアーム部101,102に取り付けた場合に、送受信部110,114は、実施の形態1と同様に、電磁誘導によって電力を無線で伝送するように、関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で配置される。そのため、無線コネクタ200によれば、実施の形態1と同様に、アーム部101,102の間で電力を無線で伝送することができる。
また、アーム部101,102の外部での作業によって無線コネクタ200をアーム部101,102に着脱できる。これにより、例えば、不具合が生じた無線コネクタ200を正常な無線コネクタ200に容易に交換できる。従って、無線コネクタ200を容易に修理することが可能になる。
<変形例2~4>
実施の形態では、第1ユニット106と第2ユニット107とが、互いに接触することなく離間している例を説明した。しかし、第1ユニット106と第2ユニット107とは、適宜接触するように構成されてもよい。
実施の形態では、第1ユニット106と第2ユニット107とが、互いに接触することなく離間している例を説明した。しかし、第1ユニット106と第2ユニット107とは、適宜接触するように構成されてもよい。
例えば回転動作を停止した時の衝撃などで、送受信部110,114の相対的な位置関係が、設計上の範囲外となる可能性がある。このような場合、電力を安定して伝送できないおそれがある。これを防ぐために、第1ユニット106と第2ユニット107とは、アーム部101,102に取り付けられた場合に、送受信部110,114の相対的な位置関係を予め定められた範囲に制限するガイド機構を含んでもよい。
変形例2~4では、ガイド機構が第1ユニット106と第2ユニット107とに設けられる例を挙げるが、ガイド機構は、第1アーム部101、第2アーム部102などに設けられてもよい。
図10に示すように、変形例2に係るガイド機構G1は、第2送受信部114の前面に設けられる比較的小さな突起G1_Aと、第1送受信部110の後面に設けられる円環状の溝G1_Bとで構成される。この場合、無線コネクタがアーム部101,102に取り付けられると、突起G1_Aの先端が溝G1_Bに嵌まって溝G1_Bの底部と接触する。溝G1_Bの底部は、幅を有する円環状の平面である。
溝G1_Bの底部が幅を有する円環状の平面であるので、第1ユニット106と第2ユニット107とは、アーム部101,102に取り付けられた場合に、設計上の回転軸と回転軸ARとがズレていても回転軸ARを中心に回転することができる。
また、突起G1_Aと溝G1_Bとの嵌り合いによって、送受信部110,114間の相対的な位置関係は予め定められた範囲に制限される。これにより、上述したように、アーム部101,102の外部に無線コネクタ100を配置した場合であっても、無線での安定した電力の伝送が可能になる。
図11に示すように、変形例3に係るガイド機構G2は、第1ハウジング108に設けられる第1突出部G2_Aと、第2ハウジング112に設けられる第1突出部G2_Bとを含む。
第1突出部G2_Aは、第2対置部123の周囲の少なくとも一部を覆い、かつ、第2対置部123の後方の少なくとも一部を覆う。第2突出部G2_Bは、第1対置部121の周囲の少なくとも一部の周囲を覆い、かつ、第1対置部121の前方の少なくとも一部を覆う。
第1突出部G2_Aは、第2対置部123との間にすき間を空けて設けられる。第2突出部G2_Bは、第1対置部121との間にすき間を空けて設けられる。これによって、第1ユニット106と第2ユニット107とは、アーム部101,102に取り付けられた場合に、設計上の回転軸と回転軸ARとがズレていても回転軸ARを中心に回転することができる。
また、第1突出部G2_Aと第2突出部G2_Bとによって、第2アーム取付部122と第1アーム取付部120との相対的な移動が制限されるので、送受信部110,114間の相対的な位置関係は予め定められた範囲に制限される。これにより、上述したように、アーム部101,102の外部に無線コネクタ100を配置した場合であっても、無線での安定した電力の伝送が可能になる。
図12に示すように、変形例4に係るガイド機構G3は、第2送受信部114に設けられており、軸心が第2の中心軸C2と概ね一致する軸部G3_Aと、第1送受信部110に設けられており、中心が第1の中心軸C1と概ね一致する穴部G3_Bとから構成される。
軸部G3_Aと穴部G3_Bとは、互いに間隔を空けて緩やかに嵌り合う。これによって、第1ユニット106と第2ユニット107とは、アーム部101,102に取り付けられた場合に、設計上の回転軸が回転軸ARからズレていても回転軸ARを中心に回転することができる。
また、軸部G3_Aと穴部G3_Bとの嵌り合いによって、第2アーム取付部122と第1アーム取付部120との相対的な移動が制限されるので、送受信部110,114間の相対的な位置関係は予め定められた範囲に制限される。これにより、上述したように、アーム部101,102の外部に無線コネクタ100を配置した場合であっても、無線での安定した電力の伝送が可能になる。
<その他の変形例>
例えば、実施の形態1では、電力を伝送対象として伝送する例を説明したが、伝送対象は情報であってもよく、電力と情報との両方であってもよい。このような場合、例えば、本実施の形態に係る無線コネクタ100の第1回路部111及び第2回路部115の構成は、伝送対象に応じて変更されるとよい。
例えば、実施の形態1では、電力を伝送対象として伝送する例を説明したが、伝送対象は情報であってもよく、電力と情報との両方であってもよい。このような場合、例えば、本実施の形態に係る無線コネクタ100の第1回路部111及び第2回路部115の構成は、伝送対象に応じて変更されるとよい。
例えば、実施の形態1では、無線コネクタ100がロボット装置のアーム部101,102に取り付けられる例を説明した。しかし、無線コネクタ100が取り付けられる対象物は、ロボット装置に限られない。第1アーム部101は第1ユニット106が取り付けられる第1対象物の一例であり、第2アーム部102は第2ユニット107が取り付けられる第2対象物の一例である。第1対象物と第2対象物とは、回転軸ARを支点にして回転可能に連結されていればよく、典型的には、各種の装置や機器に搭載され、それぞれが第1アーム部101及び第2アーム部102のように長さを有する。
例えば、実施の形態1では、送受信部110,114間における伝送対象の伝送手段が、電磁誘導である場合を例に説明した。しかし、当該伝送手段は、磁界結合の一態様である電磁誘導に限られない。当該伝送手段は、例えば、磁界結合の別の態様である磁気共鳴であってもよく、コンデンサを構成する電極間と同様の電界結合、マイクロ波や光などの電磁波の送受信などであってもよい。第1送受信部110、第2送受信部114、第1回路部111、第2回路部115などの構成は、送受信部110,114間の伝送手段に応じて変更されるとよい。
例えば、実施の形態1では、第1送受信部110が、第1対置部121の左端後方の外面に設けられ、第2送受信部114は、第2対置部123の右端前方の外面に設けられる例を説明した。第1送受信部110及び第2送受信部114を設ける箇所は、これらに限られない。第1送受信部110と第2送受信部114とは、伝送対象を無線で伝送する状態において、互いに離間して対向すればよい。
例えば、第1送受信部110と第2送受信部114とが第1ハウジング108と第2ハウジング112とのそれぞれの互いに近接する壁部に設けられればよい。詳細には例えば、第1送受信部110は、第1対置部121の左端後方の内面(すなわち、第1対置部121の内部において後方)に固定されてもよく、第1対置部121の左端後方に穴が設けられ当該穴に嵌め込まれて固定されてもよい。また詳細には例えば、第2送受信部114は、第2対置部123の右端前方の内面(すなわち、第2対置部123の内部において前方)に固定されてもよく、第2対置部123の左端後方に設けられた穴に嵌め込まれて固定されてもよい。
例えば、実施の形態1では、第1送受信部110と第2送受信部114とが円板状である例により説明した。しかし、第1送受信部110と第2送受信部114との各々の形状は、円板状に限られず、その他の形状の平板状であってもよい。また、第1送受信部110と第2送受信部114とは、平板状に限られず、例えば第1の中心軸C1に頂点を有する山型と第2の中心軸C2に底を有する谷型のような相補的な立体形状などであってもよい。第1送受信部110と第2送受信部114とのそれぞれに含まれる第1コイル部材と第2コイル部材との形状も同様に、円板状に限られず、その他の形状の平板状、相補的な立体形状などであってもよい。
例えば、実施の形態1では、第1コネクタ部109及び第1相手コネクタ部104が互いに嵌り合うことで電気的に接続する電気コネクタである例を説明した。しかし、第1コネクタ部及び第1相手コネクタ部は、電気コネクタに限られず、例えば磁界結合、電界結合、マイクロ波や光などの電磁波の送受信などによって電力を無線で伝送するための素子、部品などから構成されてもよい。第2コネクタ部113及び第2相手コネクタ部105についても同様に、電力を無線で伝送するように構成されてもよい。
例えば、実施の形態1では、第1ユニット106と第2ユニット107とが構造的に分離されている場合を例に説明した。しかし、第1ユニット106と第2ユニット107とは、構造的に分離されておらず、緩やかに連結されていてもよい。
例えば、変形例4で説明したように互いに緩やかに嵌り合う軸部と穴部とをさらに変形することで、第1ユニット106と第2ユニット107とを連結することができる。すなわち、穴部は、穴部が第1送受信部110及び第1対置部121を貫通し、軸部が当該穴部に貫通して配置されるとよい。そして、当該軸部の先端に穴部よりも大きい半径で張出す突部が設けられるとよい。当該突部は穴部に係止されるので、第1ユニット106と第2ユニット107とは連結される。しかし、軸部と穴部とは、互いに間隔を空けて緩やかに嵌り合う。
このように変形しても、第1ユニット106と第2ユニット107とは、アーム部101,102に取り付けられた場合に、設計上の回転軸が回転軸ARからズレていても回転軸ARを中心に回転することができる。また、送受信部110,114間の相対的な位置関係は予め定められた範囲に制限されるので、変形例4と同様に、アーム部101,102の外部に無線コネクタ100を配置した場合であっても、無線での安定した電力の伝送が可能になる。
<<実施の形態2>>
実施の形態1では、無線コネクタ100が送受信部110,114を含むことによって無線で電力を伝送する例を説明した。本実施の形態では、電力を伝送するための第1送受信部及び第2送受信部に加えて、情報を伝送するための第3送受信部及び第4送受信部を含む無線コネクタの例を説明する。
実施の形態1では、無線コネクタ100が送受信部110,114を含むことによって無線で電力を伝送する例を説明した。本実施の形態では、電力を伝送するための第1送受信部及び第2送受信部に加えて、情報を伝送するための第3送受信部及び第4送受信部を含む無線コネクタの例を説明する。
なお、本実施の形態に係る電力は、電力及び情報の少なくとも一方である第1伝送対象の一例であり、情報は、電力及び情報の少なくとも一方である第2伝送対象の一例である。
(実施の形態2に係る無線コネクタ300の構成)
本発明の実施の形態2に係る無線コネクタ300は、図13の分解斜視図に示すように、実施の形態1と同様の第1アーム部101と第2アーム部102との間で、電力及び情報を無線で伝送するためのコネクタである。無線コネクタ300は、アーム部101,102の外部に着脱可能に取り付けられる。本実施の形態では、磁界結合(電磁誘導)及び電磁波により無線で電力及び情報のそれぞれを伝送する例を説明する。
本発明の実施の形態2に係る無線コネクタ300は、図13の分解斜視図に示すように、実施の形態1と同様の第1アーム部101と第2アーム部102との間で、電力及び情報を無線で伝送するためのコネクタである。無線コネクタ300は、アーム部101,102の外部に着脱可能に取り付けられる。本実施の形態では、磁界結合(電磁誘導)及び電磁波により無線で電力及び情報のそれぞれを伝送する例を説明する。
無線コネクタ300は、図13に示すように、第1アーム部101と第2アーム部102とのそれぞれに外部から着脱可能に取り付けられる第1ユニット306と第2ユニット307とを備える。第1ユニット306と第2ユニット307とは、実施の形態1と同様に、互いに接触することなく離間している。
図13及び後方から見た図14に示すように、第1ユニット306は、実施の形態1と同様の第1ハウジング108と、実施の形態1とは異なる第1コネクタ部309、第1送受信部310及び第1回路部311を含む。さらに、第1ユニット306は、第3送受信部340を含む。なお、図14では、実施の形態1と同様の第1ボルト128を図示省略している。
図13及び前方から見た図15に示すように、第2ユニット307は、第1ユニット306に含まれる構成要素108,309~311,340のそれぞれに対応する構成要素112,313~315,341を含む。詳細には、第2ユニット307は、実施の形態1と同様の第2ハウジング112と、実施の形態1とは異なる第2コネクタ部313、第2送受信部314及び第2回路部315を含む。さらに、第1ユニット306は、第4送受信部341を含む。なお、図15では、実施の形態1と同様の第2ボルト129を図示省略している。
第1コネクタ部309は、第1アーム部101との間で電力及び情報を伝送するための部位である。第1コネクタ部309は、第1アーム部101の外部から第1アーム部101に取り外し可能に取り付けられることによって、第1アーム部101との間で電力及び情報を伝送する。
第1コネクタ部309は、電力を伝送するための電気接点に加えて、情報を伝送するための電気接点を含む点を除いて、実施の形態1に係る第1コネクタ部109と概ね同様に構成されるとよい。
第2コネクタ部313は、第2アーム部102との間で電力及び情報を伝送するための部位である。第2コネクタ部313は、第2アーム部102の外部から第2アーム部102に取り外し可能に取り付けられることによって、第2アーム部102との間で電力及び情報を伝送する。
第2コネクタ部313は、電力を伝送するための電気接点に加えて、情報を伝送するための電気接点を含む点を除いて、実施の形態1に係る第2コネクタ部113と概ね同様に構成されるとよい。
第1送受信部310と第2送受信部314とは、これらの間で電力を無線で伝送するための部材であって、電力を無線で伝送するように関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で配置される。典型的には、第1送受信部310と第2送受信部314とは、それぞれ、第1の中心軸C1と第2の中心軸C2とを中心とする形状であり、例えば中空の円板状である。
第1送受信部310と第2送受信部314とは、中空である点を除いて、実施の形態1に係る第1送受信部110と第2送受信部114とのそれぞれと同様に構成されるとよい。すなわち、本実施の形態に係る第1送受信部310と第2送受信部314とは、それぞれ、中空円板状の第1コイル部材と第2コイル部材とである。
第3送受信部340と第4送受信部341とは、これらの間で情報を無線で伝送するための部材であって、情報を無線で伝送するように関節機構103の外部で回転軸ARに沿って互いに離間して対向した状態で配置される。典型的には、第3送受信部340と第2送受信部321とは、それぞれ、第1の中心軸C1と第2の中心軸C2とを中心とする形状であり、例えば円板状である。
第3送受信部340と第4送受信部341とは、それぞれ、第1送受信部310と第2送受信部314との内部に設けられる。
言い換えると、第1送受信部310は、概ね共通の第1の中心軸C1を中心として、第3送受信部340の周囲に設けられる。第2送受信部314は、概ね共通の第2の中心軸C2を中心として、第4送受信部341の周囲に設けられる。
第3送受信部340と第4送受信部341とは、これらが配置される箇所及び伝送方法を除いて、実施の形態1に係る第1送受信部110と第2送受信部114とのそれぞれと同様に構成されるとよい。すなわち、本実施の形態に係る第3送受信部340と第4送受信部341とは、それぞれ、円板状の第1アンテナ部材と第2アンテナ部材とである。
第1回路部311は、第1コネクタ部309と第1送受信部310と第3送受信部340とに電気的に接続される電気回路である。第1回路部311は、情報を送信及び/又は受信するための情報の送受信回路をさらに含む点を除いて、実施の形態1に係る第1回路部111と概ね同様に構成されるとよい。ここで、「送信及び/又は受信すること」は、送信と受信との一方又は両方を行うことを意味し、以下においても同様である。
第2回路部315は、第2コネクタ部313と第2送受信部314と第4送受信部341とに電気的に接続される電気回路である。第2回路部315は、情報を送信及び/又は受信するための情報の送受信回路をさらに含む点を除いて、実施の形態1に係る第2回路部115と概ね同様に構成されるとよい。
本実施の形態においても、第1ユニット306と第2ユニット307とは、互いに接触することなく離間している。そのため、実施の形態1と同様に、第1ユニット306と第2ユニット307とは、アーム部101,102に取り付けられた場合に、設計上の回転軸が回転軸ARからズレていても、アーム部101,102の屈曲に伴って回転軸ARを中心に回転することができる。
(実施の形態2に係る無線コネクタ300の動作)
これまで、本発明の実施の形態2に係る無線コネクタ300の構成について説明した。ここから、本実施の形態に係る無線コネクタ300の動作について、図16の回路構成図を参照して説明する。
これまで、本発明の実施の形態2に係る無線コネクタ300の構成について説明した。ここから、本実施の形態に係る無線コネクタ300の動作について、図16の回路構成図を参照して説明する。
送受信部310,314は、上述したように、回転軸ARに沿って互いに離間して対向した状態で配置される。これにより、図16に示すように、第1回路部311に含まれる送電回路に接続された第1送受信部110と、第2回路部315に含まれる受電回路に接続された第2送受信部314とが、電磁誘導によって磁界結合することができる。そのため、図6を参照して説明した無線コネクタ100と同様に動作することによって、第1アーム部101と第2アーム部102との間で電力を無線で伝送することができる。ここで、「送受信部310,314」は、第1送受信部310と第2送受信部314との総称であり、以下においても同様である。
送受信部310,314は、回転軸ARに沿って互いに離間して対向した状態で配置されるので、第1ユニット106と第2ユニット107とが回転軸ARを中心として回転した場合においても、電磁誘導によって磁界結合する。これにより、無線コネクタ300は、実施の形態1に係る送受信部110,114と同様に、アーム部101,102の屈伸の状態及び動作に関わらず、第1アーム部101と第2アーム部102との間で電力を無線で伝送することができる。
送受信部340,341についてはマイクロ波や光などの電磁波により無線で情報を伝送する。ここで、「送受信部340,341」は、第3送受信部340と第4送受信部341との総称であり、以下においても同様である。
すなわち、送受信部340,341は、上述したように、回転軸ARに沿って互いに離間して対向した状態で配置される。これにより、図16に示すように、第1回路部311に含まれる情報の送受信に接続された第3送受信部340と、第2回路部315に含まれる情報の送受信回路に接続された第4送受信部341とが、電磁波を互いに送受信することができる。そのため、例えば、第1アーム部101からの情報を含む電気信号は、第1コネクタ部309と第1回路部311(情報の送受信回路)とを通じて第3送受信部340に伝送され、当該情報を含む電磁波となって、第4送受信部341に受信される。第4送受信部341は、受信した電磁波を、当該電磁波に含まれた情報を含む電気信号に変換して出力する。第4送受信部341からの情報を含む電気信号は、第2回路部315(情報の送受信回路)と第2コネクタ部313とを通じて、第2アーム部102へ伝送される。このような動作により、第1アーム部101から第2アーム部102へ情報を無線で伝送することができる。
なお、第2アーム部102から第1アーム部101へ情報を伝送する場合は、上述とは逆の順で伝送されればよい。
すなわち、第2アーム部102からの情報を含む電気信号は、第2コネクタ部313と第2回路部315(情報の送受信回路)とを通じて第4送受信部341に伝送され、当該情報を含む電磁波となって、第3送受信部340に受信される。第3送受信部340は、受信した電磁波を、当該電磁波に含まれた情報を含む電気信号に変換して出力する。第3送受信部340からの情報を含む電気信号は、第1回路部311(情報の送受信回路)と第1コネクタ部309とを通じて、第1アーム部101へ伝送される。
送受信部340,341は、回転軸ARに沿って互いに離間して対向した状態で配置されるので、第1ユニット106と第2ユニット107とが回転軸ARを中心として回転した場合においても、無線で情報を伝送する。これにより、無線コネクタ300は、アーム部101,102の屈伸の状態及び動作に関わらず、上述のように動作することができるので、第1アーム部101と第2アーム部102との間で情報を無線で伝送することができる。
(実施の形態2に係る無線コネクタ着脱方法)
これまで、本発明の実施の形態2に係る無線コネクタ300の動作について説明した。ここから、本実施の形態に係る無線コネクタ着脱方法について説明する。
これまで、本発明の実施の形態2に係る無線コネクタ300の動作について説明した。ここから、本実施の形態に係る無線コネクタ着脱方法について説明する。
本実施の形態に係る無線コネクタ着脱方法は、無線コネクタ300をアーム部101,102に着脱するための方法であって、無線コネクタ300の取り付け方法と取り外し方法とを含む。無線コネクタ300の取り付け方法はと取り外し方法とは、上述した実施の形態1に係る無線コネクタ100の取り付け方法及び取り外し方法のそれぞれと同様である。すなわち、実施の形態1に係る無線コネクタ着脱方法の説明において、実施の形態1に係る無線コネクタ100の構成要素を、それぞれに対応する実施の形態2に係る無線コネクタ300の構成要素に置き換えるとよい。説明の簡略化のため、無線コネクタ300の取り付け方法と取り外し方法の詳細な説明は省略する。
これまで、本発明の実施の形態2について説明した。
本実施の形態においても、アーム部101,102の外部での作業によって無線コネクタ300をアーム部101,102に着脱することができる。これにより、例えば、不具合が生じた無線コネクタ300を正常な無線コネクタ300に容易に交換することができる。従って、アーム部101,102に無線コネクタ300を容易に修理することが可能になる。その他、本実施の形態においても、実施の形態1と同様の効果を奏する。
また本実施の形態では、送受信部310,314だけでなく、送受信部340,341も、概ね互いに平行に配置される。送受信部340,341の相対的な位置関係を制限することによって、送受信部340,341は、実施の形態1に係る送受信部110,114と同様に、アーム部101,102の屈伸状態及び屈伸動作に関わらず、予め定められた範囲の比較的安定した強さで磁界結合することができる。従って、アーム部101,102の外部に無線コネクタ300を配置した場合であっても、無線での安定した電力及び情報の伝送が可能になる。
以上、本発明の実施の形態及び変形例について説明したが、本発明は、これらに限られるものではない。例えば、本発明は、これまで説明した実施の形態及び変形例の一部又は全部を適宜組み合わせた形態、その形態に適宜変更を加えた形態をも含む。
本出願は、2019年12月16日に出願された、日本国特許出願特願2019-226372号に基づく。本明細書中に日本国特許出願特願2019-226372号の明細書、特許請求の範囲、図面全体を参照として取り込むものとする。
100,200,300 無線コネクタ
101 第1アーム部
102 第2アーム部
103 関節機構
103A 軸部
103B 孔部
104 第1相手コネクタ部
105 第2相手コネクタ部
106,206,306 第1ユニット
107,207,307 第2ユニット
108,208 第1ハウジング
109,209,309 第1コネクタ部
110,310 第1送受信部
111,311 第1回路部
112,212 第2ハウジング
113,213,313 第2コネクタ部
114,314 第2送受信部
115,315 第2回路部
120,220 第1アーム取付部
121 第1対置部
122,222 第2アーム取付部
123 第2対置部
124 第1開口
125 第1ボルト孔
126 第2開口
127 第2ボルト孔
128 第1ボルト
129 第2ボルト
130,230 第1導線
131,231 第2導線
132 第2ボルト穴部
133 第1ボルト穴部
340 第3送受信部
341 第4送受信部
OS1,OS2 外殻
AR 回転軸
C1 第1の中心軸
C2 第2の中心軸
S1,S2 シールド部材
G1~G3 ガイド機構
G1_A 突起
G1_B 溝
G2_A 第1突出部
G2_B 第2突出部
G3_A 軸部
G3_B 穴部
Claims (14)
- 回転軸を支点にして回転可能に連結された第1対象物と第2対象物との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタを前記第1対象物及び前記第2対象物に着脱するための無線コネクタ着脱方法であって、
前記無線コネクタは、
前記伝送対象を無線で伝送するための第1送受信部、及び、前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部が固定された第1ハウジングと、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部、及び、前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部が固定された第2ハウジングとを備え、
前記第1対象物の外部から前記第1コネクタ部を前記第1対象物に取り付け、前記第2対象物の外部から前記第2コネクタ部を前記第2対象物に取り付けることによって、前記第1送受信部と前記第2送受信部とが前記伝送対象を無線で伝送するように互いに離間して対向した状態で前記第1対象物及び前記第2対象物に前記無線コネクタを取り付けることと、
前記第1対象物の外部での作業によって前記第1コネクタ部を前記第1対象物から取り外し、前記第2対象物の外部での作業によって前記第2コネクタ部を前記第2対象物から取り外すことによって、前記第1対象物及び前記第2対象物から前記無線コネクタを取り外すことを含む
ことを特徴とする無線コネクタ着脱方法。 - 回転軸を支点にして回転可能に連結する関節機構を介して連結された第1アーム部及び第2アーム部と、
前記第1アーム部と前記第2アーム部との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタとを備え、
前記第1アーム部は、前記第1アーム部の外部に露出した第1相手コネクタ部を含み、
前記第2アーム部は、前記第2アーム部の外部に露出した第2相手コネクタ部を含み、
前記無線コネクタは、
前記伝送対象を無線で伝送するための第1送受信部、及び、前記第1相手コネクタに取り外し可能に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部が固定された第1ハウジングと、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部、及び、前記第2相手コネクタに取り外し可能に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部が固定された第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1コネクタ部と前記第2コネクタ部とがそれぞれ前記第1相手コネクタ部と前記第2相手コネクタ部とに取り付けられた場合に、前記関節機構の外部で前記伝送対象を無線で伝送するように前記回転軸に沿って互いに離間して対向した状態で配置される
ことを特徴とするロボット装置。 - 第1対象物と第2対象物との間で、電力である第1伝送対象を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記第1伝送対象を無線で伝送するための第1送受信部と、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記第1伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部と前記第1コネクタ部とが固定された第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記第1伝送対象を無線で伝送するための第2送受信部と、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記第1伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部と前記第2コネクタ部とが固定された第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第1伝送対象を無線で伝送するように互いに離間して対向した状態で配置される
ことを特徴とする無線コネクタ。 - 前記第1送受信部は、前記第1伝送対象を伝送するための平板状の第1コイル部材を含み、
前記第2送受信部は、前記第1コイル部材と磁界結合することによって前記第1伝送対象を伝送するための平板状の第2コイル部材を含み、
前記第1コイル部材と前記第2コイル部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第1伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置される
ことを特徴とする請求項3に記載の無線コネクタ。 - 前記第1ユニットは、
前記第1ハウジングに固定されており、情報である第2伝送対象を無線で伝送するための第3送受信部をさらに含み、
前記第2ユニットは、
前記第2ハウジングに固定されており、前記第3送受信部との間で前記第2伝送対象を無線で伝送するための第4送受信部をさらに含み、
前記第1コネクタ部は、前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記第1伝送対象及び前記第2伝送対象を伝送し、
前記第2コネクタ部は、前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記第1伝送対象及び前記第2伝送対象を伝送し、
前記第3送受信部と前記第4送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第2伝送対象を無線で伝送するように互いに離間して対向した状態で配置される
ことを特徴とする請求項3又は4に記載の無線コネクタ。 - 前記第3送受信部は、情報である前記第2伝送対象を伝送するための第1アンテナ部材を含み、
前記第4送受信部は、前記第2伝送対象を伝送するための第2アンテナ部材を含み、
前記第1送受信部は、前記第3送受信部の周囲に設けられ
前記第2送受信部は、前記第4送受信部の周囲に設けられ、
前記第1アンテナ部材と前記第2アンテナ部材とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記第2伝送対象を無線で伝送するように互いに離間して対向した状態で平行に配置される
ことを特徴とする請求項5に記載の無線コネクタ。 - 第1対象物と第2対象物との間で、伝送対象である電力及び情報の少なくとも一方を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1コイル部材を含む第1送受信部と、
前記第1対象物の外部から前記第1対象物に嵌め合わされることによって、前記第1対象物との間で前記伝送対象を伝送するように前記第1対象物に取り外し可能に取り付けられる第1コネクタ部と、
前記第1コイル部材と前記第1コネクタ部とが固定される第1ハウジングとを含み、
前記第2ユニットは、
前記第1コイル部材との間で前記伝送対象を無線で伝送するための第2コイル部材を含む第2送受信部と、
前記第2対象物の外部から前記第2対象物に嵌め合わされることによって、前記第2対象物との間で前記伝送対象を伝送するように前記第2対象物に取り外し可能に取り付けられる第2コネクタ部と、
前記第2コイル部材と前記第2コネクタ部とが固定される第2ハウジングとを含み、
前記第1コネクタ部と前記第2コネクタ部とは、嵌合方向が同じ方向であり、
前記第1コイル部材と前記第2コイル部材とは、前記嵌合方向に沿って互いに離間して対向した状態で配置されることによって磁界結合する
ことを特徴とする無線コネクタ。 - 前記第1コイル部材は、第1の中心軸の周りに配置されており、
前記第2コイル部材は、第2の中心軸の周りに配置されており、
前記第1の中心軸と前記第2の中心軸とは、前記嵌合方向と平行である
ことを特徴とする請求項7に記載の無線コネクタ。 - 第1対象物と第2対象物との間で、伝送対象である電力及び情報の少なくとも一方を無線で伝送するための無線コネクタであって、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1コイル部材を含む第1送受信部と、
前記第1対象物の外部から前記第1対象物に取り外し可能に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部と前記第1コネクタ部とが固定される第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2コイル部材を含む第2送受信部と、
前記第2対象物の外部から前記第2対象物に取り外し可能に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部と前記第2コネクタ部とが固定される第2ハウジングとを含み、
前記第1コイル部材と前記第2コイル部材とは、互いに磁界結合する状態では、互いに離間して対向している
ことを特徴とする無線コネクタ。 - 第1対象物と第2対象物との間で、電力及び情報の少なくとも一方である伝送対象を無線で伝送するための無線コネクタであって、
第1対象物の外部から前記第1対象物に取り外し可能に取り付けられる第1ユニットと、
第2対象物の外部から前記第2対象物に取り外し可能に取り付けられる第2ユニットとを備え、
前記第1ユニットは、
前記伝送対象を無線で伝送するための第1送受信部と、
前記第1対象物に取り付けられることによって前記第1対象物との間で前記伝送対象を伝送するための第1コネクタ部と、
前記第1送受信部が固定され、前記第1コネクタ部が取り付けられる第1ハウジングとを含み、
前記第2ユニットは、
前記第1送受信部との間で前記伝送対象を無線で伝送するための第2送受信部と、
前記第2対象物に取り付けられることによって前記第2対象物との間で前記伝送対象を伝送するための第2コネクタ部と、
前記第2送受信部が固定され、前記第2コネクタ部が取り付けられる第2ハウジングとを含み、
前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記伝送対象を無線で伝送するように互いに離間した状態で対向して配置される
ことを特徴とする無線コネクタ。 - 前記第1対象物と前記第2対象物とは、回転軸を支点にして回転可能に連結されている
ことを特徴とする請求項3から10のいずれか1項に記載の無線コネクタ。 - 前記第1送受信部と前記第2送受信部とは、前記第1ユニット及び前記第2ユニットのそれぞれが前記第1対象物及び前記第2対象物に取り付けられた場合に、前記回転軸に沿って互いに離間した状態で対向して配置される
ことを特徴とする請求項11に記載の無線コネクタ。 - 前記第1ユニットと前記第2ユニットとは、前記第1対象物及び前記第2対象物のそれぞれに取り付けられた場合に、互いに離間している
ことを特徴とする請求項3から12のいずれか1項に記載の無線コネクタ。 - 前記第1ユニットと前記第2ユニットとは、前記第1対象物及び前記第2対象物のそれぞれに取り付けられた場合に、前記第1送受信部と前記第2送受信部との相対的な位置関係を予め定められた範囲に制限するガイド機構をさらに含む
ことを特徴とする請求項3から13のいずれか1項に記載の無線コネクタ。
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US17/767,850 US12162140B2 (en) | 2019-12-16 | 2020-10-02 | Wireless connector attachment/detachment method, robot device, and wireless connector |
| CN202080081182.3A CN114746228B (zh) | 2019-12-16 | 2020-10-02 | 无线连接器安装/拆卸方法、机器人设备和无线连接器 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019226372A JP6872000B1 (ja) | 2019-12-16 | 2019-12-16 | 無線コネクタ着脱方法、ロボット装置及び無線コネクタ |
| JP2019-226372 | 2019-12-16 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2021124648A1 true WO2021124648A1 (ja) | 2021-06-24 |
Family
ID=75896294
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/037580 Ceased WO2021124648A1 (ja) | 2019-12-16 | 2020-10-02 | 無線コネクタ着脱方法、ロボット装置及び無線コネクタ |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12162140B2 (ja) |
| JP (1) | JP6872000B1 (ja) |
| CN (1) | CN114746228B (ja) |
| WO (1) | WO2021124648A1 (ja) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025022506A1 (ja) * | 2023-07-21 | 2025-01-30 | 株式会社アドテックス | ワイヤレス給電システム |
Citations (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0819985A (ja) * | 1994-07-04 | 1996-01-23 | Mitsubishi Electric Corp | ロボット装置 |
| JPH09300270A (ja) * | 1996-05-21 | 1997-11-25 | Shinko Electric Co Ltd | 多関節ロボットのハンド部給電装置 |
| US20080197710A1 (en) * | 2004-11-30 | 2008-08-21 | Abb Research Ltd. | Transmission Of Power Supply For Robot Applications Between A First Member And A Second Member Arranged Rotatable Relative To One Another |
| JP2012518382A (ja) * | 2009-02-13 | 2012-08-09 | ウィットリシティ コーポレイション | 損失性環境における無線エネルギー伝達 |
| CN203086197U (zh) * | 2013-01-16 | 2013-07-24 | 光碁科技股份有限公司 | 具电线收纳功能的电力感应式充电器 |
| JP2017144530A (ja) * | 2016-02-19 | 2017-08-24 | パナソニックIpマネジメント株式会社 | 電動装置 |
| JP2018512830A (ja) * | 2015-02-10 | 2018-05-17 | カスケード コーポレイションCascade Corporation | 産業機器用ワイヤレスパワー伝送及び通信 |
| KR20190078107A (ko) * | 2017-12-26 | 2019-07-04 | 재단법인경북테크노파크 | 산업용 로봇의 회전축 선 꼬임 방지가 가능한 무선전력전송 장치 |
| JP2019213330A (ja) * | 2018-06-04 | 2019-12-12 | Nittoku株式会社 | 自走式搬送装置及びその充電方法 |
| JP2020163498A (ja) * | 2019-03-28 | 2020-10-08 | キヤノン株式会社 | ロボット装置、ロボット装置の制御方法、ロボット装置を用いた物品の製造方法、無線給電モジュール、制御プログラム及び記録媒体 |
Family Cites Families (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR101850527B1 (ko) * | 2011-03-25 | 2018-04-19 | 삼성전자주식회사 | 휴대용 디바이스 및 휴대용 디바이스의 무선 전력 충전 시스템 |
| JP5559296B2 (ja) * | 2012-12-19 | 2014-07-23 | ファナック株式会社 | 機械の制御機器 |
| CN106560978B (zh) * | 2015-10-02 | 2021-06-29 | 松下知识产权经营株式会社 | 无线电力传输系统 |
| KR101950765B1 (ko) * | 2016-11-21 | 2019-02-22 | 고소영 | 다중결합이 가능한 무선충전 트레이 유닛 및 이를 포함하는 무선충전 시스템 |
| JP7033718B2 (ja) | 2017-01-13 | 2022-03-11 | パナソニックIpマネジメント株式会社 | 送電装置、および当該送電装置を備える無線電力伝送システム |
| CN109917157A (zh) * | 2017-12-13 | 2019-06-21 | 清华四川能源互联网研究院 | 一种无线充电系统的自动测试系统 |
| JPWO2019189138A1 (ja) * | 2018-03-29 | 2021-04-01 | パナソニックIpマネジメント株式会社 | 伝送モジュールおよび無線電力データ伝送装置 |
| JP6625689B2 (ja) * | 2018-05-24 | 2019-12-25 | 日本無線株式会社 | コイル部材、非接触型電力伝送装置、電磁波照射/受信装置、電力伝送/情報通信装置及び自律可動型ロボットシステム |
| WO2020174819A1 (ja) * | 2019-02-28 | 2020-09-03 | パナソニックIpマネジメント株式会社 | 伝送モジュールおよび無線電力データ伝送装置 |
-
2019
- 2019-12-16 JP JP2019226372A patent/JP6872000B1/ja active Active
-
2020
- 2020-10-02 CN CN202080081182.3A patent/CN114746228B/zh active Active
- 2020-10-02 WO PCT/JP2020/037580 patent/WO2021124648A1/ja not_active Ceased
- 2020-10-02 US US17/767,850 patent/US12162140B2/en active Active
Patent Citations (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0819985A (ja) * | 1994-07-04 | 1996-01-23 | Mitsubishi Electric Corp | ロボット装置 |
| JPH09300270A (ja) * | 1996-05-21 | 1997-11-25 | Shinko Electric Co Ltd | 多関節ロボットのハンド部給電装置 |
| US20080197710A1 (en) * | 2004-11-30 | 2008-08-21 | Abb Research Ltd. | Transmission Of Power Supply For Robot Applications Between A First Member And A Second Member Arranged Rotatable Relative To One Another |
| JP2012518382A (ja) * | 2009-02-13 | 2012-08-09 | ウィットリシティ コーポレイション | 損失性環境における無線エネルギー伝達 |
| CN203086197U (zh) * | 2013-01-16 | 2013-07-24 | 光碁科技股份有限公司 | 具电线收纳功能的电力感应式充电器 |
| JP2018512830A (ja) * | 2015-02-10 | 2018-05-17 | カスケード コーポレイションCascade Corporation | 産業機器用ワイヤレスパワー伝送及び通信 |
| JP2017144530A (ja) * | 2016-02-19 | 2017-08-24 | パナソニックIpマネジメント株式会社 | 電動装置 |
| KR20190078107A (ko) * | 2017-12-26 | 2019-07-04 | 재단법인경북테크노파크 | 산업용 로봇의 회전축 선 꼬임 방지가 가능한 무선전력전송 장치 |
| JP2019213330A (ja) * | 2018-06-04 | 2019-12-12 | Nittoku株式会社 | 自走式搬送装置及びその充電方法 |
| JP2020163498A (ja) * | 2019-03-28 | 2020-10-08 | キヤノン株式会社 | ロボット装置、ロボット装置の制御方法、ロボット装置を用いた物品の製造方法、無線給電モジュール、制御プログラム及び記録媒体 |
Also Published As
| Publication number | Publication date |
|---|---|
| US12162140B2 (en) | 2024-12-10 |
| CN114746228A (zh) | 2022-07-12 |
| JP6872000B1 (ja) | 2021-05-19 |
| JP2021094629A (ja) | 2021-06-24 |
| CN114746228B (zh) | 2024-03-19 |
| US20240033949A1 (en) | 2024-02-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101887538B1 (ko) | 무성별 결합이 가능한 모듈 연결장치 | |
| KR101980269B1 (ko) | 모듈 연결 시스템 | |
| US10879961B2 (en) | Male connector, female connector, and connection structure of male connector and female connector | |
| KR20160057723A (ko) | 자동차용 카메라 모듈 | |
| JP7118532B2 (ja) | コネクタ、及び、電力供給システム | |
| KR102868732B1 (ko) | 전도성 충전 시스템을 위한 전기 커넥터, 커넥터 어셈블리 및 충전 로봇 | |
| JP6872000B1 (ja) | 無線コネクタ着脱方法、ロボット装置及び無線コネクタ | |
| JP6872050B1 (ja) | ロボット装置及び無線コネクタ | |
| US8210854B2 (en) | Electrical socket assembly for electrically connecting adjacent circuit boards | |
| JP2000237464A (ja) | 組立自在な制御用ブロック | |
| KR20160003183U (ko) | 커넥터를 구비한 케이블 조립체 및 커넥터 조립체 | |
| JP6995941B1 (ja) | 無線コネクタ着脱方法、ロボット装置、無線コネクタ及び無線コネクタユニット | |
| JP7103831B2 (ja) | 非接触通信モジュール及び電子機器 | |
| JP6694040B2 (ja) | 雄コネクタ、雌コネクタ及び雄コネクタと雌コネクタと接続構造 | |
| CN223584000U (zh) | 一种电机总成 | |
| CN121031639A (zh) | 电子标签 | |
| CN118472676A (zh) | 连接器 | |
| KR100464555B1 (ko) | 접속이 용이한 인터페이스장치를 구비한 로봇의 모듈 | |
| JPH0745324A (ja) | コネクタ | |
| JPH11122830A (ja) | 電気自動車充電用コネクタ |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20901914 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 17767850 Country of ref document: US |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20901914 Country of ref document: EP Kind code of ref document: A1 |