EP1893491B1 - VORRICHTUNG ZUM BEFÜLLEN UND VERSCHLIEßEN VON BEHÄLTNISSEN - Google Patents
VORRICHTUNG ZUM BEFÜLLEN UND VERSCHLIEßEN VON BEHÄLTNISSEN Download PDFInfo
- Publication number
- EP1893491B1 EP1893491B1 EP06755119A EP06755119A EP1893491B1 EP 1893491 B1 EP1893491 B1 EP 1893491B1 EP 06755119 A EP06755119 A EP 06755119A EP 06755119 A EP06755119 A EP 06755119A EP 1893491 B1 EP1893491 B1 EP 1893491B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- filling
- closing
- movement
- containers
- container
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Lifetime
Links
Images
Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B7/00—Closing containers or receptacles after filling
- B65B7/16—Closing semi-rigid or rigid containers or receptacles not deformed by, or not taking-up shape of, contents, e.g. boxes or cartons
- B65B7/28—Closing semi-rigid or rigid containers or receptacles not deformed by, or not taking-up shape of, contents, e.g. boxes or cartons by applying separate preformed closures, e.g. lids, covers
- B65B7/2821—Closing semi-rigid or rigid containers or receptacles not deformed by, or not taking-up shape of, contents, e.g. boxes or cartons by applying separate preformed closures, e.g. lids, covers applying plugs or threadless stoppers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B3/00—Packaging plastic material, semiliquids, liquids or mixed solids and liquids, in individual containers or receptacles, e.g. bags, sacks, boxes, cartons, cans, or jars
- B65B3/003—Filling medical containers such as ampoules, vials, syringes or the like
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B39/00—Nozzles, funnels or guides for introducing articles or materials into containers or wrappers
- B65B39/12—Nozzles, funnels or guides for introducing articles or materials into containers or wrappers movable towards or away from container or wrapper during filling or depositing
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B39/00—Nozzles, funnels or guides for introducing articles or materials into containers or wrappers
- B65B39/14—Nozzles, funnels or guides for introducing articles or materials into containers or wrappers movable with a moving container or wrapper during filling or depositing
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B65/00—Details peculiar to packaging machines and not otherwise provided for; Arrangements of such details
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B39/00—Nozzles, funnels or guides for introducing articles or materials into containers or wrappers
- B65B2039/009—Multiple outlets
Definitions
- the present invention relates to a device for filling and closing of containers according to the preamble of the independent claim.
- a device according to the preamble of claim 1 is already known from DE-A-103 30 700 known.
- the machine for filling and closing packaging disclosed therein comprises several processing stations.
- the processing stations each have a robot, wherein the robot each processing station have a robot of the same design.
- a processing station for the filling operation operates independently of a processing station, by which a closure is attached to a still open side of a syringe.
- the erfmdungswashe apparatus for filling and closing of containers with the characterizing feature of claim 1 has the advantage that an immediate closing can be done after filling. Since the filled syringes remain open only for a short period of time, the likelihood of contamination is reduced. By changing the distance of filling and closing devices in the transport direction of the containers to be filled, the output can also be increased.
- a three-axis robot is used as a means of movement for moving the filling device.
- Such robots are well known and have fast operating speeds. As a result, the output of the device for filling and closing of containers can be further increased.
- the transport device is operated in clocked operation.
- the possibility of a variable distance between filling and closing device represents a further optimization in terms of short residence time filled containers and application capacity.
- the device can be adapted to different processing steps by the distance between the filling and closing is chosen sufficiently large, that after filling the filled containers are to be taken out again for the purpose of in-process control,
- the movement means are controlled as a function of the speed of the transport device.
- the containers can be filled and / or closed during transport.
- a transport device 14 18 equipped with containers nests 16 are transported to different processing stations.
- the open containers 18 are filled by a filling device 10 which supplies the containers 18 to the liquid via filling needles 22 arranged in a row.
- the filling device 10 can be moved by a movement device 28 at least in the transport direction of the transport device 14 and in the vertical direction.
- the closing device 12 consists at least of setting tubes 24 and tappets 26 with which the filled containers 18 are closed.
- a further movement device 30 is provided, which also allows a movement of the closing device 12 in the transport direction and in the vertical direction.
- a centering device is brought during the processing operation under the respective nest 16 with the containers 18 in order to keep the containers 18 in a defined and stable position.
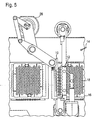
- the second embodiment according to the FIGS. 4 and 5 differs from the previous one in that the movement device 30 'of the closing device 12 only allows a movement in the vertical direction, but not in Transport direction.
- a corresponding linear guide is in FIG. 4 shown.
- a movement device 28 of the filling device 10 a robot is used, the filling needles 22 moves in the transport direction, perpendicular to the transport direction and in the vertical direction.
- the first embodiment of the invention operates as follows: The transport of the containers 18 carrying nests 16 is carried out one behind the other. Thus, a plurality of nests 16 with containers 18 in series in centerings. They are driven one after the other to the workstations. There is now a simultaneous filling and closing instead of by the filling device 10 and the closing device 12. According to the filling needles 22 can now also perform a movement in the transport direction. The transport device 14 performs a clocked movement in order to always drive the containers 18 exactly under the closing device 12. The movement of the filling needles 22 of the filling device 10 can compensate for the offset between the nests 16. So is how in FIG. 1 shown filled the last row of the first nest 16 and at the same time the immediately following row closed by the closing device 12.
- the subsequent processing step is in FIG. 2 shown.
- the inflator 10 now moves to the next nest 16 to fill the next row.
- the conveyor 14 advances one position to close the next row. Characterized in that the distance between the filling device 10 and closing device 12 is variably selected, the filling device 10 may begin with the filling of the next nest 16, thereby increasing the output.
- the movement device 30 generates the closing movement with setting tube 24 and plunger 26.
- an in-process control as in FIG. 3 shown.
- the device described is preferably suitable for a timed operation of the transport device 14. However, it could also be used for a continuously running transport device.
- the device shown differs only in the movement device 30 of the closing device 12. This now does not allow movement of the closing device 12 in the transport direction.
- the nests 16 are moved in dependence on the closing position.
- the movement device 28 of the filling device 10 is designed as a robot, which can also carry out movements in the transport direction in addition to vertical and horizontal movements. This can in principle also in the FIGS. 1 to 3 reach shown different processing positions.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Filling Of Jars Or Cans And Processes For Cleaning And Sealing Jars (AREA)
- Basic Packing Technique (AREA)
- Supplying Of Containers To The Packaging Station (AREA)
Description
- Vorliegende Erfindung betrifft eine Vorrichtung zum Befüllen und Verschließen von Behältnissen nach dem Oberbegriff des unabhängigen Anspruchs. Eine Vorrichtung nach dem Oberbegriff des Anspruchs 1 ist bereits aus der
DE-A-103 30 700 bekannt. Die dort offenbarte Maschine zum Füllen und Verschließen von Verpackungen umfasst mehrere Bearbeitungsstationen. Die Bearbeitungsstationen weisen jeweils einen Roboter auf, wobei die Roboter jeder Bearbeitungsstation eine baugleiche Robotermechanik besitzen. Eine Bearbeitungsstation für den Füllvorgang arbeitet unabhängig von einer Bearbeitungsstation, durch die ein Verschluss an einer noch offen Seite einer Spritze angebracht wird. - Die erfmdungsgemäße Vorrichtung zum Befüllen und Verschließen von Behältnissen mit dem kennzeichnenden Merkmal des Anspruchs 1 hat demgegenüber den Vorteil, dass ein sofortiges Verschließen nach dem Füllen erfolgen kann. Da die gefüllten Spritzen nur über eine geringe Zeitspanne offen bleiben, reduziert sich die Wahrscheinlichkeit von Verschmutzungen. Durch Veränderung des Abstands von Befülleinrichtungen und Verschließeinrichtungen in Transportrichtung der zu befüllenden Behältnisse kann außerdem die Ausbringung erhöht werden.
- In einer zweckmäßigen Weiterbildung ist vorgesehen, dass als Bewegungsmittel ein Dreiachsroboter verwendet ist zur Bewegung der Befülleinrichtung. Solche Roboter sind hinlänglich bekannt und weisen schnelle Arbeitsgeschwindigkeiten auf. Dadurch lässt sich die Ausbringung der Vorrichtung zum Befüllen und Verschließen von Behältnissen weiter erhöhen.
- In einer zweckmäßigen Weiterbildung ist vorgesehen, dass die Transporteinrichtung im getakteten Betrieb betrieben wird. Gerade für eine getaktete Transporteinrichtung stellt die Möglichkeit eines variablen Abstands zwischen Befülleinrichtung und Verschließeinrichtung eine weitere Optimierung hinsichtlich kurzer Verweildauer befüllter Behältnisse und Ausbringungskapazität dar. Zudem kann die Vorrichtung an unterschiedliche Bearbeitungsschritte angepasst werden, indem der Abstand zwischen Befülleinrichtung und Verschließeinrichtung so hinreichend groß gewählt wird, dass nach dem Befüllen die befüllten Behältnisse zum Zweck der In-Prozesskontrolle wieder zu entnehmen sind,
- In einer zweckmäßigen Weiterbildung ist vorgesehen, dass die Bewegungsmittel in Abhängigkeit von der Geschwindigkeit der Transporteinrichtung angesteuert sind. So können die Behältnisse während des laufenden Transports befüllt und/oder verschlossen werden.
- In einer zweckmäßigen Weiterbildung ist vorgesehen, dass lediglich die Befülleinrichtung in Transportrichtung verfahren werden kann, während die Verschließeinrichtung gegenüber der Transporteinrichtung eine feste Position einnimmt und lediglich in vertikaler Richtung zum Verschließen bewegt werden kann. Bei dieser gewählten Konstellation lassen sich die Kosten der Vorrichtung weiter optimieren, jedoch erhöht sich dadurch die Zeit zwischen Füllen und Verschließen, da eine Leerreihe dazwischen liegt.
- Vorteilhafte Weiterbildungen der erfindungsgemäßen Vorrichtung zum Befüllen und Verschließen von Behältnissen ergeben sich aus den abhängigen Ansprüchen und aus der Beschreibung.
- Zwei Ausführungsbeispiele der Erfindung sind in der Zeichnung dargestellt und werden nachfolgend näher erläutert. Es zeigen:
-
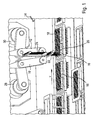
Figur 1 eine perspektivische Ansicht der erfindungsgemäßen Vorrichtung in der Position "letzte Reihe füllen, vorletzte Reihe Verschließen", -
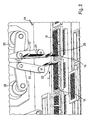
Figur 2 die erfindungsgemäße Vorrichtung derFigur 1 in der Position "erste Reihe füllen, letzte Reihe Verschließen", - die
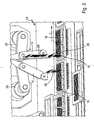
Figur 3 die erfindungsgemäße Vorrichtung derFigur 1 in der Stellung "In-Prozesskontrolle", - die
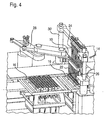
Figur 4 ein zweites Ausführungsbeispiel der erfindungsgemäßen Vorrichtung sowie -
Figur 5 die Draufsicht auf die erfindungsgemäße Vorrichtung derFigur 4 . - Beschreibung der Ausführungsbeispiele
- Auf einer Transporteinrichtung 14 werden mit Behältnissen 18 bestückte Nester 16 zu unterschiedlichen Bearbeitungsstationen transportiert. Die offen Behältnisse 18 werden durch eine Befülleinrichtung 10 befüllt, die Flüssigkeit über in einer Reihe angeordneten Füllnadeln 22 den Behältnissen 18 zuführt. Die Befülleinrichtung 10 kann durch eine Bewegungseinrichtung 28 zumindest in Transportrichtung der Transporteinrichtung 14 sowie in vertikaler Richtung bewegt werden. Dadurch lässt sich ein variabler Abstand zwischen den Füllnadeln 22 der Befülleinrichtung 10 und einer Verschließeinrichtung 12 herstellen. Die Verschließeinrichtung 12 besteht zumindest aus Setzrohren 24 und Stößeln 26, mit denen die befüllten Behältnisse 18 verschlossen werden. Zudem ist eine weitere Bewegungseinrichtung 30 vorgesehen, die eine Bewegung der Verschließeinrichtung 12 ebenfalls in Transportrichtung sowie in vertikaler Richtung ermöglicht. Dieselbe Anordnung ist auch in den
Figuren 2 und3 gezeigt, wenn auch in unterschiedlichen Positionen, wie nachfolgend erläutert. Eine Zentriereinrichtung wird während des Bearbeitungsvorgangs unter das jeweilige Nest 16 mit den Behältnissen 18 gebracht, um die Behältnisse 18 in definierter und stabiler Position zu halten. - Das zweite Ausführungsbeispiel gemäß den
Figuren 4 und5 unterscheidet sich von dem vorhergehenden darin, dass die Bewegungseinrichtung 30'der Verschließeinrichtung 12 lediglich eine Bewegung in vertikaler Richtung zulässt, nicht jedoch in Transportrichtung. Eine entsprechende Linearführung ist inFigur 4 gezeigt. Als Bewegungseinrichtung 28 der Befülleinrichtung 10 kommt ein Roboter zum Einsatz, der Füllnadeln 22 in Transportrichtung, senkrecht zur Transportrichtung und in vertikaler Richtung bewegt. - Das erfindungsgemäße erste Ausführungsbeispiel arbeitet wie folgt: Der Durchtransport der die Behältnisse 18 tragenden Nester 16 erfolgt hintereinander. Somit sind mehrere Nester 16 mit Behältnissen 18 in Reihe in Zentrierungen. Sie werden nacheinander zu den Arbeitsstationen gefahren. Es findet nun ein gleichzeitiges Füllen und Verschließen statt durch die Befülleinrichtung 10 und die Verschließeinrichtung 12. Erfindungsgemäß können nun die Füllnadeln 22 auch eine Bewegung in Transportrichtung ausführen. Die Transporteinrichtung 14 führt eine getaktete Bewegung aus, um die Behältnisse 18 immer genau unter die Verschließeinrichtung 12 zu fahren. Die Bewegung der Füllnadeln 22 der Befülleinrichtung 10 kann den Versatz zwischen den Nestern 16 ausgleichen. So wirdwie in
Figur 1 gezeigt- die letzte Reihe des ersten Nests 16 befüllt und zugleich die unmittelbar darauf folgende Reihe durch die Verschließeinrichtung 12 verschlossen. Der darauf folgende Bearbeitungsschritt ist inFigur 2 dargestellt. Die Befülleinrichtung 10 bewegt sich nun zum nächsten Nest 16, um dort die nächste Reihe zu füllen. Die Transporteinrichtung 14 fährt eine Position weiter, um die nächste Reihe zu Verschließen. Dadurch, dass der Abstand zwischen Befülleinrichtung 10 und Verschließeinrichtung 12 variabel gewählt wird, kann die Befülleinrichtung 10 bereits mit der Befüllung des nächsten Nestes 16 beginnen, wodurch sich die Ausbringung erhöht. Die Bewegungseinrichtung 30 erzeugt die Verschließbewegung mit Setzrohr 24 und Stößel 26. - Durch die variable Position der Füllnadeln 22 kann dies auch für ein Füllen etwas weiter entfernter Behältnisse 18 benutzt werden, um diese dann einer In-Prozesskontrolle zu unterwerfen, wie in
Figur 3 gezeigt. Es kann beispielsweise notwendig werden, wenn man die Behältnisse 18 nach dem Füllen und vor dem Verschließen wieder zum Wiegen entnehmen muss. Bei direkt hintereinander angeordneten Stationen ist dies nicht möglich. Die beschriebene Vorrichtung eignet sich bevorzugter Weise für einen getakteten Betrieb der Transporteinrichtung 14. Sie könnte jedoch auch für eine kontinuierlich laufende Transporteinrichtung zum Einsatz kommen. - Die in
Figur 4 und5 gezeigte Vorrichtung unterscheidet sich lediglich in der Bewegungseinrichtung 30 der Verschließeinrichtung 12. Diese ermöglicht nun nicht eine Bewegung der Verschließeinrichtung 12 in Transportrichtung. Die Nester 16 werden in Abhängigkeit von der Verschließposition verfahren. Die Bewegungseinrichtung 28 der Befülleinrichtung 10 ist als Roboter ausgeführt, der neben Vertikal- und Horizontalbewegungen auch Bewegungen in Transportrichtung vornehmen kann. Damit lassen sich prinzipiell auch die in denFiguren 1 bis 3 gezeigten unterschiedlichen Bearbeitungspositionen erreichen. - Als zu befüllende Behältnisse 18 kommen beispielsweise Spritzen zum Einsatz.
Claims (11)
- Vorrichtung zum Befüllen und Verschließen von Behältnissen, mit einer Befülleinrichtung (10) zum Befüllen von zumindest einem Behältnis (18), mit einer Verschließeinrichtung (12) zum Verschließen zumindest des Behältnisses (18),
mit einer Transporteinrichtung (14) zum Zuführen zumindest des Behältnisses (18) zu der Befülleinrichtung (10) und der Verschließeinrichtung (12), dadurch gekennzeichnet, dass zumindest eine Bewegungseinrichtung (28, 30) vorgesehen ist zur Veränderung des Abstandes in Transportrichtung von Befülleinrichtung (10) und Verschließeinrichtung (12). - Vorrichtung nach Anspruch 1, dadurch gekennzeichnet, dass die Transporteinrichtung (14) Nester (16) bewegt, in denen mehrere Behältnisse (18) anordenbar sind.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Transporteinrichtung (14) getaktet betrieben ist.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Bewegungseinrichtungen (28, 30) Befülleinrichtung (10) und Verschließeinrichtung (12) so verfahren, dass sie unmittelbar benachbarte Reihen des Nests (16) befüllen bzw. verschließen können.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass lediglich die Bewegungseinrichtung (28) der Befülleinrichtung (10) eine Bewegung in Transportrichtung ermöglicht.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Bewegungseinrichtung (28, 30) auch senkrecht zur Transportrichtung verfahrbar ist.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Befülleinrichtung (10) zumindest eine Füllnadel (12) umfasst.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Verschließeinrichtung (12) zumindest ein Setzrohr (24) und/oder zumindest einen Stößel (26) umfasst.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass als Bewegungseinrichtung (28) ein Roboter vorgesehen ist.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass Bewegungseinrichtungen (28, 30) Befülleinrichtung (10) und Verschließeinrichtung (12) so verfahren, dass die Befülleinrichtung (10) eine erste Reihe eines darauf folgenden Nests (16) befüllt, während die Verschließeinrichtung (12) die letzte Reihe des vorhergehenden Nests (16) verschließt.
- Vorrichtung nach einem der vorhergehenden Ansprüche, dadurch gekennzeichnet, dass die Bewegungseinrichtung (28) der Befülleinrichtung (10) einen hinreichend großen Abstand zu der Verschließeinrichtung (12) vorsieht, um befüllte Behältnisse (18) einer In-Prozesskontrolle zuzuführen.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE102005026986A DE102005026986A1 (de) | 2005-06-10 | 2005-06-10 | Vorrichtung zum Befüllen und Verschließen von Behältnissen |
| PCT/EP2006/062185 WO2006131433A1 (de) | 2005-06-10 | 2006-05-10 | VORRICHTUNG ZUM BEFÜLLEN UND VERSCHLIEßEN VON BEHÄLTNISSEN |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP1893491A1 EP1893491A1 (de) | 2008-03-05 |
| EP1893491B1 true EP1893491B1 (de) | 2009-08-05 |
| EP1893491B2 EP1893491B2 (de) | 2013-01-23 |
Family
ID=36599357
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP06755119A Expired - Lifetime EP1893491B2 (de) | 2005-06-10 | 2006-05-10 | VORRICHTUNG ZUM BEFÜLLEN UND VERSCHLIEßEN VON BEHÄLTNISSEN |
Country Status (6)
| Country | Link |
|---|---|
| US (1) | US7937907B2 (de) |
| EP (1) | EP1893491B2 (de) |
| CN (1) | CN101193798B (de) |
| AT (1) | ATE438569T1 (de) |
| DE (2) | DE102005026986A1 (de) |
| WO (1) | WO2006131433A1 (de) |
Families Citing this family (35)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US7628184B2 (en) * | 2003-11-07 | 2009-12-08 | Medical Instill Technologies, Inc. | Adjustable needle filling and laser sealing apparatus and method |
| DE102008001287A1 (de) * | 2008-04-21 | 2009-10-22 | Robert Bosch Gmbh | Füll- und Verschließmaschine für Behälter |
| IT1391065B1 (it) * | 2008-10-17 | 2011-11-18 | Co Ri M A S R L | Macchina per il riempimento di fiale |
| DE102009027452A1 (de) | 2009-07-03 | 2011-01-05 | Robert Bosch Gmbh | Vorrichtung zum Füllen und Verschließen von pharmazeutischen Bahältnissen |
| FR2955563B1 (fr) * | 2010-01-26 | 2013-09-06 | Spc France | Machine pour remplir une pluralite de recipients, systeme incluant une telle machine et procede de fabrication afferent |
| US8499531B2 (en) * | 2010-10-19 | 2013-08-06 | Aalba Dent Inc. | System and method for packaging dental ingots |
| US10524980B2 (en) * | 2016-09-13 | 2020-01-07 | Vanrx Pharmasystems, Inc. | Apparatus and method for aseptically filling pharmaceutical containers with a pharmaceutical fluid using rotary stage |
| US10723497B2 (en) | 2014-11-03 | 2020-07-28 | Vanrx Pharmasystems Inc. | Apparatus and method for monitoring and controlling the filling of a container with a pharmaceutical fluid in an aseptic environment |
| US20180072446A1 (en) | 2016-09-13 | 2018-03-15 | Vanrx Pharmasystems Inc. | Apparatus and method for asepticaly filling pharmaceutical containers with a pharmaceutical fluid using rotary stage |
| DE102011113358A1 (de) * | 2011-09-15 | 2013-03-21 | Groninger & Co. Gmbh | Verfahren und Vorrichtung zum Füllen und Verschließen von pharmazeutischen Objekten |
| CN105050636B (zh) | 2012-11-12 | 2017-11-03 | 肖特股份有限公司 | 用于医疗、制药或化妆品应用的物质的容器的加工或处理方法和设备 |
| TW201900139A (zh) | 2013-08-16 | 2019-01-01 | 加拿大商凡爾克斯醫藥系統公司 | 用於裝填藥物容器的方法、裝置及系統 |
| US12515832B2 (en) | 2013-08-16 | 2026-01-06 | Vanrx Pharmasystems Inc. | Method, device and system for filling pharmaceutical containers |
| CN103600872B (zh) * | 2013-10-21 | 2015-11-25 | 尚宝泰机械科技(昆山)有限公司 | 一种全自动食品生产包装设备 |
| PL3119678T3 (pl) * | 2014-03-21 | 2019-03-29 | G.D Societa' Per Azioni | Urządzenie i sposób do wytwarzania wkładów do papierosów elektronicznych |
| US9868555B2 (en) * | 2014-04-28 | 2018-01-16 | Robert F. LiVolsi | Systems and methods for filling inoculations |
| FR3020800B1 (fr) * | 2014-05-09 | 2017-08-25 | Pierre Fabre Dermo Cosmetique | Dispositif et procede de remplissage aseptique |
| JP2016068999A (ja) * | 2014-09-29 | 2016-05-09 | 澁谷工業株式会社 | Xyテーブルの駆動装置およびxyテーブルを備えた容器処理装置 |
| WO2016069221A1 (en) * | 2014-10-30 | 2016-05-06 | Pharmajet Inc | Needle free syringe and pre-filling system |
| US10071021B2 (en) | 2015-05-19 | 2018-09-11 | Maxocap Corporation | Capsule filling systems and methods of using a capsule filling system |
| JP6911257B2 (ja) * | 2015-06-11 | 2021-07-28 | アイ.エム.エー. インダストリア マシーン オートマチック エス.ピー.エー. イン シグラ アイエムエー エス.ピー.エー.I.M.A. Industria Macchine Automatiche S.P.A In Sigla Ima S.P.A | ビン、カートリッジ、シリンジなどの充填および密封の為の方法および機械 |
| US11530064B2 (en) * | 2016-09-13 | 2022-12-20 | Vanrx Pharmasystems Inc. | Apparatus and method for monitoring and controlling the removal of a cover from a sealed tube in an aseptic environment |
| DE102017100010A1 (de) * | 2017-01-02 | 2018-07-05 | Groninger & Co. Gmbh | Vorrichtung und Verfahren zum Befüllen genesteter Gebinde |
| IT201700072715A1 (it) * | 2017-06-29 | 2018-12-29 | Gd Spa | Sistema per l’assemblaggio ed il riempimento di sigarette elettroniche |
| CN107444683A (zh) * | 2017-07-31 | 2017-12-08 | 贵州天地药业有限责任公司 | 一种针剂灌装机 |
| DE102017124908A1 (de) * | 2017-10-24 | 2019-04-25 | Schott Ag | Verfahren und Vorrichtung zur flexiblen Behandlung von Pharma-Packmitteln |
| DE102019201950A1 (de) * | 2019-02-14 | 2020-08-20 | Syntegon Technology Gmbh | Vorrichtung und Verfahren zum Einlegen von Mischkugeln in pharmazeutische Behältnisse |
| GB201906419D0 (en) * | 2019-05-07 | 2019-06-19 | Cwm Automation Ltd | Filling cups |
| US12043495B2 (en) * | 2020-06-25 | 2024-07-23 | Euromatic S.R.L. | Extraction device of glass containers for pharmaceutical and/or cosmetic use and extraction pincer |
| CN112794256B (zh) * | 2020-12-31 | 2025-04-29 | 楚天科技股份有限公司 | 用于高速灌装加塞的系统及方法 |
| IT202100028877A1 (it) | 2021-11-15 | 2023-05-15 | Ima Spa | Apparecchiatura e procedimento per confezionare automaticamente contenitori. |
| US12037150B2 (en) | 2022-01-31 | 2024-07-16 | Vanrx Pharmasystems Inc. | Apparatus and method for monitoring and controlling the aseptic filling and sealing of pharmaceutical containers with a pharmaceutical fluid using rotary stage |
| DE102024112135A1 (de) * | 2024-04-30 | 2025-10-30 | Syntegon Technology Gmbh | Vorrichtung, Set und Verfahren zum Befüllen und/oder Verschließen von Behältnissen |
| DE102024121722A1 (de) * | 2024-07-30 | 2026-02-05 | Bausch + Ströbel SE + Co. KG | Aufnahmevorrichtung für einen Träger für pharmazeutische Behälter und Anlage zum Verarbeiten pharmazeutischer Behälter |
| DE102024121673A1 (de) * | 2024-07-30 | 2026-02-05 | Bausch + Ströbel SE + Co. KG | Vorrichtung zum Verarbeiten pharmazeutischer Behälter |
Family Cites Families (27)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5143422B2 (de) * | 1972-04-18 | 1976-11-22 | ||
| IT992236B (it) * | 1973-08-21 | 1975-09-10 | Cioni E | Macchina per il riempimento e la saldatura di fiale di vetro a ciclo multiplo |
| US4096683A (en) | 1977-02-16 | 1978-06-27 | Cozzoli Machine Company | Ampoule filling and sealing machine |
| JPS61297041A (ja) | 1985-06-26 | 1986-12-27 | Matsushita Electric Ind Co Ltd | ロボットを用いた作業装置 |
| US4918907A (en) * | 1988-01-20 | 1990-04-24 | T W Kutter Inc. | Forming and filling flexible plastic packaging |
| DE3819095A1 (de) † | 1988-06-04 | 1989-12-07 | Ruchozki Manfred Dipl Ing Fh | Fuell- und verschliessmaschine fuer einwegspritzen |
| JPH0326480A (ja) * | 1989-06-21 | 1991-02-05 | Mitsubishi Electric Corp | 産業用ロボツト装置及びこの産業用ロボツト装置のロボツト教示方法 |
| JPH072481B2 (ja) * | 1989-11-14 | 1995-01-18 | 鐘紡株式会社 | 化粧料等の充填・包装装置 |
| JP3162207B2 (ja) | 1991-11-14 | 2001-04-25 | 三菱原子燃料株式会社 | 燃料棒における端栓の溶接装置及び溶接方法 |
| US5385004A (en) * | 1992-10-28 | 1995-01-31 | Ossid Corporation | Packaging machine having a conveyor of controllable length |
| CN2205358Y (zh) * | 1994-03-29 | 1995-08-16 | 锦州市食品包装机械研究所 | 微机控制pvc/pe瓶自动成型灌装机 |
| JP3512127B2 (ja) * | 1994-12-23 | 2004-03-29 | 株式会社イシダ | 製袋包装機の横シ−ル機構 |
| GB9515248D0 (en) * | 1995-07-25 | 1995-09-20 | Thurne Eng Co Ltd | Packaging machine |
| DE19604100C2 (de) | 1996-02-06 | 1997-12-18 | Bosch Gmbh Robert | Vorrichtung zum Handhaben von in einem nach oben offenen Behälter angeordneten, befüllbaren, rohrförmigen Gegenständen |
| US5842321A (en) * | 1996-08-06 | 1998-12-01 | Advanced Mechanical Technologies, Inc. | System and apparatus for filling and capping a vial |
| DE19716846C1 (de) * | 1997-04-22 | 1998-11-19 | Bosch Gmbh Robert | Evakuier- und Verschließvorrichtung |
| DE19818762A1 (de) * | 1998-04-27 | 1999-10-28 | Khs Masch & Anlagenbau Ag | Füllsystem sowie Füllelement |
| US5971041A (en) * | 1998-06-22 | 1999-10-26 | Kalish Canada Inc. | Container filling apparatus with walking nozzles bank |
| DE29907459U1 (de) * | 1999-04-27 | 1999-07-29 | Norden Pac Development Ab, Kalmar | Verpackungsmaschine |
| US6418982B1 (en) * | 2000-11-21 | 2002-07-16 | Amphastar Pharmaceuticals Inc. | Process of bulk filling |
| DE10322556A1 (de) * | 2002-09-27 | 2004-04-08 | Robert Bosch Gmbh | Vorrichtung zum Behandeln von Behältnissen, insbesondere zum Füllen und Verschließen derselben |
| DE10246061B4 (de) * | 2002-10-02 | 2012-09-06 | Robert Bosch Gmbh | Verfahren zum Befüllen von pharmazeutischen Behältnissen wie Ampullen, Vials o.ä. |
| US20040079051A1 (en) * | 2002-10-25 | 2004-04-29 | Lippman Glenn W. | Semi-automatic vial closing apparatus |
| US7065936B2 (en) * | 2002-12-18 | 2006-06-27 | Formax, Inc. | Fill and packaging apparatus |
| US7140592B2 (en) | 2002-12-31 | 2006-11-28 | Cardinal Health 303, Inc. | Self-sealing male Luer connector with biased valve plug |
| DE10330700A1 (de) * | 2003-07-08 | 2005-01-27 | Robert Bosch Gmbh | Maschine zum Füllen und Verschließen von Verpackungen |
| CN2693654Y (zh) * | 2004-01-17 | 2005-04-20 | 汕头市粤东机械厂有限公司 | 准确定位的充填封口机 |
-
2005
- 2005-06-10 DE DE102005026986A patent/DE102005026986A1/de not_active Ceased
-
2006
- 2006-05-10 WO PCT/EP2006/062185 patent/WO2006131433A1/de not_active Ceased
- 2006-05-10 EP EP06755119A patent/EP1893491B2/de not_active Expired - Lifetime
- 2006-05-10 CN CN2006800206135A patent/CN101193798B/zh not_active Expired - Lifetime
- 2006-05-10 DE DE502006004456T patent/DE502006004456D1/de not_active Expired - Lifetime
- 2006-05-10 US US11/912,032 patent/US7937907B2/en not_active Expired - Lifetime
- 2006-05-10 AT AT06755119T patent/ATE438569T1/de active
Also Published As
| Publication number | Publication date |
|---|---|
| US7937907B2 (en) | 2011-05-10 |
| CN101193798B (zh) | 2010-06-23 |
| US20080184671A1 (en) | 2008-08-07 |
| WO2006131433A1 (de) | 2006-12-14 |
| DE502006004456D1 (de) | 2009-09-17 |
| ATE438569T1 (de) | 2009-08-15 |
| DE102005026986A1 (de) | 2006-12-14 |
| CN101193798A (zh) | 2008-06-04 |
| EP1893491A1 (de) | 2008-03-05 |
| EP1893491B2 (de) | 2013-01-23 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP1893491B2 (de) | VORRICHTUNG ZUM BEFÜLLEN UND VERSCHLIEßEN VON BEHÄLTNISSEN | |
| DE4010024B4 (de) | Fertigungsanlage mit Parallel- und Nebenförderwegen | |
| DE102015103833B3 (de) | Verbessertes Transportsystem, insbesondere für eine Füll- und Verschließanlage für pharmazeutische oder kosmetische Objekte | |
| EP1595797B1 (de) | Verpackungsmaschine und Verfahren zum Zuführen von Behältern in einer Verpackungsmaschine | |
| EP3339221A2 (de) | Vorrichtung und verfahren zum handhaben von produkten | |
| EP1598273A1 (de) | Verpackungsmaschine und Verfahren zum Verschliessen von Behältern | |
| DE102015209618A1 (de) | Transportvorrichtung | |
| EP3442886B1 (de) | Rundschalttisch und verfahren zum transport von objekten | |
| DE102016106360A1 (de) | System und Verfahren zum Handhaben von Artikeln wie Getränkebehältnissen oder dergleichen | |
| WO2026027411A1 (de) | Vorrichtung und verfahren zum verarbeiten pharmazeutischer behälter | |
| EP3056440B1 (de) | Verpackungsanlage mit Objektträger | |
| DE102009003542A1 (de) | Handhabungs- und/oder Packmaschine zur Handhabung von Verpackungsgütern und Verfahren zu deren Steuerung | |
| DE102020109565A1 (de) | Verpackungsvorrichtung und Verfahren zum Verpacken von Artikeln | |
| EP4469376A1 (de) | Transportsystem, vorrichtung mit einem transportsystem und verfahren | |
| EP1389166A2 (de) | Vorrichtung zum einschieben von packgut in packmittel | |
| DE102010049588A1 (de) | Schalenverschließmaschine und Verfahren zum Betrieb einer solchen Schalenverschließmaschine | |
| EP1636097B1 (de) | Vorrichtung und verfahren zum bearbeiten von kontinuierlich auf trägerelementen bereitgestellten packungen | |
| DE102015224874A1 (de) | Vorrichtung zum Umgang mit Artikeln | |
| DE102018108221A1 (de) | Verpackungsvorrichtung und Verfahren zum Umrüsten und/oder Ausrüsten einer Verpackungsvorrichtung | |
| DE102020111767A1 (de) | Regalbediengerät | |
| DE19853365A1 (de) | Verfahren und Vorrichtung zum Umformen | |
| DE102017001828B3 (de) | Transporteinrichtung zum Transport von Objekten von Arbeitsstation zu Arbeitsstation einer Produktionsanlage und Produktionsanlage zur Herstellung von Produkten mit einer derartigen Transporteinrichtung | |
| WO2005070768A1 (de) | Tuben-handhabungsvorrichtung und verfahren zu deren steuerung | |
| WO2021004801A2 (de) | Verfahren zum transportieren von werkstückteilen | |
| DE102017122703A1 (de) | Vorrichtung zum Einlegen von Produkten |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| 17P | Request for examination filed |
Effective date: 20080110 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC NL PL PT RO SE SI SK TR |
|
| DAX | Request for extension of the european patent (deleted) | ||
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC NL PL PT RO SE SI SK TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REF | Corresponds to: |
Ref document number: 502006004456 Country of ref document: DE Date of ref document: 20090917 Kind code of ref document: P |
|
| LTIE | Lt: invalidation of european patent or patent extension |
Effective date: 20090805 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20091116 Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20091205 |
|
| NLV1 | Nl: lapsed or annulled due to failure to fulfill the requirements of art. 29p and 29m of the patents act | ||
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FD4D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20091205 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20091105 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: IE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 |
|
| PLBI | Opposition filed |
Free format text: ORIGINAL CODE: 0009260 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 |
|
| PLAX | Notice of opposition and request to file observation + time limit sent |
Free format text: ORIGINAL CODE: EPIDOSNOBS2 |
|
| 26 | Opposition filed |
Opponent name: BAUSCH + STROEBEL MASCHINENFABRIK ILSHOFEN GMBH + Effective date: 20100505 |
|
| PLBB | Reply of patent proprietor to notice(s) of opposition received |
Free format text: ORIGINAL CODE: EPIDOSNOBS3 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20091106 |
|
| BERE | Be: lapsed |
Owner name: ROBERT BOSCH G.M.B.H. Effective date: 20100531 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100531 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20100510 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST Effective date: 20110131 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100531 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100531 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100510 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100510 Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20100206 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20090805 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MM01 Ref document number: 438569 Country of ref document: AT Kind code of ref document: T Effective date: 20110510 |
|
| PUAH | Patent maintained in amended form |
Free format text: ORIGINAL CODE: 0009272 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: PATENT MAINTAINED AS AMENDED |
|
| 27A | Patent maintained in amended form |
Effective date: 20130123 |
|
| AK | Designated contracting states |
Kind code of ref document: B2 Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC NL PL PT RO SE SI SK TR |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110510 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: AELC |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: AELC |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R102 Ref document number: 502006004456 Country of ref document: DE Effective date: 20130123 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20130123 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R082 Ref document number: 502006004456 Country of ref document: DE Representative=s name: DREISS PATENTANWAELTE PARTG MBB, DE Ref country code: DE Ref legal event code: R081 Ref document number: 502006004456 Country of ref document: DE Owner name: SYNTEGON TECHNOLOGY GMBH, DE Free format text: FORMER OWNER: ROBERT BOSCH GMBH, 70469 STUTTGART, DE Ref country code: DE Ref legal event code: R081 Ref document number: 502006004456 Country of ref document: DE Owner name: SYNTEGON TECHNOLOGY GMBH, DE Free format text: FORMER OWNER: ROBERT BOSCH PACKAGING TECHNOLOGY GMBH, 71332 WAIBLINGEN, DE |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PUE Owner name: SYNTEGON TECHNOLOGY GMBH, DE Free format text: FORMER OWNER: ROBERT BOSCH GMBH, DE |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250519 Year of fee payment: 20 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20250530 Year of fee payment: 20 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: CH Payment date: 20250601 Year of fee payment: 20 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R081 Ref document number: 502006004456 Country of ref document: DE Owner name: SYNTEGON TECHNOLOGY GMBH, DE Free format text: FORMER OWNER: SYNTEGON TECHNOLOGY GMBH, 71332 WAIBLINGEN, DE |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: R18 Free format text: ST27 STATUS EVENT CODE: U-0-0-R10-R18 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260213 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: H14 Free format text: ST27 STATUS EVENT CODE: U-0-0-H10-H14 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260510 |