WO2021153050A1 - 制御装置 - Google Patents
制御装置 Download PDFInfo
- Publication number
- WO2021153050A1 WO2021153050A1 PCT/JP2020/046664 JP2020046664W WO2021153050A1 WO 2021153050 A1 WO2021153050 A1 WO 2021153050A1 JP 2020046664 W JP2020046664 W JP 2020046664W WO 2021153050 A1 WO2021153050 A1 WO 2021153050A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- torque
- motor temperature
- temperature
- motor
- torque limit
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images



Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60L—PROPULSION OF ELECTRICALLY-PROPELLED VEHICLES; SUPPLYING ELECTRIC POWER FOR AUXILIARY EQUIPMENT OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRODYNAMIC BRAKE SYSTEMS FOR VEHICLES IN GENERAL; MAGNETIC SUSPENSION OR LEVITATION FOR VEHICLES; MONITORING OPERATING VARIABLES OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRIC SAFETY DEVICES FOR ELECTRICALLY-PROPELLED VEHICLES
- B60L15/00—Methods, circuits, or devices for controlling the traction-motor speed of electrically-propelled vehicles
- B60L15/20—Methods, circuits, or devices for controlling the traction-motor speed of electrically-propelled vehicles for control of the vehicle or its driving motor to achieve a desired performance, e.g. speed, torque, programmed variation of speed
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60L—PROPULSION OF ELECTRICALLY-PROPELLED VEHICLES; SUPPLYING ELECTRIC POWER FOR AUXILIARY EQUIPMENT OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRODYNAMIC BRAKE SYSTEMS FOR VEHICLES IN GENERAL; MAGNETIC SUSPENSION OR LEVITATION FOR VEHICLES; MONITORING OPERATING VARIABLES OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRIC SAFETY DEVICES FOR ELECTRICALLY-PROPELLED VEHICLES
- B60L15/00—Methods, circuits, or devices for controlling the traction-motor speed of electrically-propelled vehicles
- B60L15/02—Methods, circuits, or devices for controlling the traction-motor speed of electrically-propelled vehicles characterised by the form of the current used in the control circuit
- B60L15/06—Methods, circuits, or devices for controlling the traction-motor speed of electrically-propelled vehicles characterised by the form of the current used in the control circuit using substantially sinusoidal AC
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P27/00—Arrangements or methods for the control of AC motors characterised by the kind of supply voltage
- H02P27/04—Arrangements or methods for the control of AC motors characterised by the kind of supply voltage using variable-frequency supply voltage, e.g. inverter or converter supply voltage
- H02P27/06—Arrangements or methods for the control of AC motors characterised by the kind of supply voltage using variable-frequency supply voltage, e.g. inverter or converter supply voltage using DC to AC converters or inverters
- H02P27/08—Arrangements or methods for the control of AC motors characterised by the kind of supply voltage using variable-frequency supply voltage, e.g. inverter or converter supply voltage using DC to AC converters or inverters with pulse width modulation
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P29/00—Arrangements for regulating or controlling electric motors, appropriate for both AC and DC motors
- H02P29/60—Controlling or determining the temperature of the motor or of the drive
- H02P29/62—Controlling or determining the temperature of the motor or of the drive for raising the temperature of the motor
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60L—PROPULSION OF ELECTRICALLY-PROPELLED VEHICLES; SUPPLYING ELECTRIC POWER FOR AUXILIARY EQUIPMENT OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRODYNAMIC BRAKE SYSTEMS FOR VEHICLES IN GENERAL; MAGNETIC SUSPENSION OR LEVITATION FOR VEHICLES; MONITORING OPERATING VARIABLES OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRIC SAFETY DEVICES FOR ELECTRICALLY-PROPELLED VEHICLES
- B60L2240/00—Control parameters of input or output; Target parameters
- B60L2240/40—Drive Train control parameters
- B60L2240/42—Drive Train control parameters related to electric machines
- B60L2240/423—Torque
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60L—PROPULSION OF ELECTRICALLY-PROPELLED VEHICLES; SUPPLYING ELECTRIC POWER FOR AUXILIARY EQUIPMENT OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRODYNAMIC BRAKE SYSTEMS FOR VEHICLES IN GENERAL; MAGNETIC SUSPENSION OR LEVITATION FOR VEHICLES; MONITORING OPERATING VARIABLES OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRIC SAFETY DEVICES FOR ELECTRICALLY-PROPELLED VEHICLES
- B60L2240/00—Control parameters of input or output; Target parameters
- B60L2240/40—Drive Train control parameters
- B60L2240/42—Drive Train control parameters related to electric machines
- B60L2240/425—Temperature
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60L—PROPULSION OF ELECTRICALLY-PROPELLED VEHICLES; SUPPLYING ELECTRIC POWER FOR AUXILIARY EQUIPMENT OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRODYNAMIC BRAKE SYSTEMS FOR VEHICLES IN GENERAL; MAGNETIC SUSPENSION OR LEVITATION FOR VEHICLES; MONITORING OPERATING VARIABLES OF ELECTRICALLY-PROPELLED VEHICLES; ELECTRIC SAFETY DEVICES FOR ELECTRICALLY-PROPELLED VEHICLES
- B60L2240/00—Control parameters of input or output; Target parameters
- B60L2240/40—Drive Train control parameters
- B60L2240/52—Drive Train control parameters related to converters
- B60L2240/526—Operating parameters
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P2207/00—Indexing scheme relating to controlling arrangements characterised by the type of motor
- H02P2207/05—Synchronous machines, e.g. with permanent magnets or DC excitation
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P25/00—Arrangements or methods for the control of AC motors characterised by the kind of AC motor or by structural details
- H02P25/02—Arrangements or methods for the control of AC motors characterised by the kind of AC motor or by structural details characterised by the kind of motor
- H02P25/022—Synchronous motors
- H02P25/03—Synchronous motors with brushless excitation
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02T—CLIMATE CHANGE MITIGATION TECHNOLOGIES RELATED TO TRANSPORTATION
- Y02T10/00—Road transport of goods or passengers
- Y02T10/60—Other road transportation technologies with climate change mitigation effect
- Y02T10/64—Electric machine technologies in electromobility
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02T—CLIMATE CHANGE MITIGATION TECHNOLOGIES RELATED TO TRANSPORTATION
- Y02T10/00—Road transport of goods or passengers
- Y02T10/60—Other road transportation technologies with climate change mitigation effect
- Y02T10/72—Electric energy management in electromobility
Definitions
- the present invention relates to a control device.
- electric vehicles such as electric vehicles and hybrid vehicles may break down due to the temperature of the motor rising and becoming overheated if the overloaded state of the motor continues due to long-time high-speed running or climbing a slope. .. Therefore, a technique for limiting the output torque according to the temperature state of the motor is required.
- Patent Document 1 discloses a technique capable of more effectively suppressing heat generation of a motor during regenerative control by lowering the temperature at which motor output limitation in regenerative control is started to be lower than the temperature in power running control.
- Patent Document 2 discloses a technique capable of changing the temperature limit of the motor according to a predetermined standard of the rate of change of the motor temperature, and simultaneously protecting the temperature of the motor and exhibiting its performance.
- Patent Document 2 there is a method of changing the inclination of the torque limit map according to the temperature change, but the point where the motor temperature and the limit torque are balanced changes depending on the amount of temperature rise before the start of the torque limit, and the output is continuous.
- the problem is that the performance of the motor cannot be fully exhibited due to the low torque that can be produced.
- the control device includes a PWM generator that outputs a PWM drive signal to the inverter, and a torque limiter that outputs a torque command after limiting to the PWM generator based on a torque command from a higher-level control unit and a motor temperature.
- the torque limit unit is output from the torque limit coefficient calculation unit that calculates the torque limit coefficient based on the motor temperature, the torque command from the upper control unit, and the torque limit coefficient calculation unit.
- a post-limit torque calculation unit that outputs the post-restriction torque command to the PWM generation unit based on the torque limit coefficient, and the torque limit coefficient calculation unit has a motor temperature higher than a predetermined temperature.
- the output torque of the motor is limited based on the motor temperature, and when the time change rate of the motor temperature is larger than the predetermined value, the time change rate of the motor temperature is equal to or less than the predetermined value. In comparison, the torque is limited so that the torque changes gently.
- the output of the motor does not decrease more than necessary.
- FIG. 1 is a diagram showing a configuration of a control device 60 showing a first embodiment of the present invention.
- the voltage of the DC power supply 10 is output to the inverter 40 via the contactor 20, the DC voltage is converted into an AC voltage, and the converted AC voltage is converted into an AC motor 30 (IPMSM. Hereinafter, the motor 30). ), And also controls the motor 30.
- a secondary battery such as a nickel hydrogen battery or a lithium ion battery is used as the DC power supply 10. At that time, the voltage is expected to be several hundred V, and the output shaft of the motor 30 is assumed to be connected to the axle.
- inverter 40 elements such as IGBTs that perform high-speed switching are arranged for three phases on the positive electrode side and the negative electrode side of the DC power supply 10.
- a pulse width modulation method or the like is adopted in which the pulse width of the voltage generated from the inverter 40 is changed by switching of the six switching elements 41 in total and a predetermined voltage is applied to the motor 30.
- the control device 60 includes a torque limiting unit and a PWM generating unit 63.
- the torque limiting unit includes a torque limiting coefficient calculating unit 61 and a post-limiting torque calculating unit 62.
- the torque limit coefficient calculation unit 61 limits the torque limit coefficient Lmt and then torques based on the motor temperature value Tm acquired from the motor temperature sensor 50 (hereinafter, sensor 50) that detects the temperature of the motor 30 (hereinafter, motor temperature). Calculated by the calculation unit 62.
- the specific calculation method of the torque limit coefficient Lmt will be described later in FIG.
- the post-limit torque calculation unit 62 multiplies the torque command Trq from the upper controller (upper control unit) by the torque limit coefficient Lmt acquired from the torque limit coefficient calculation unit 61, and outputs the post-limit torque command Trq * to the PWM generation unit 63. Output to.
- the PWM generation unit 63 generates a PWM drive signal so that a torque close to the actual value is output based on the restricted torque command Trq * acquired from the restricted torque calculation unit 62.
- the generated PWM drive signal is output to the inverter 40.
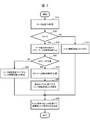
- FIG. 2 is an example of a flowchart of the control device 60 according to the first embodiment of the present invention.
- FIGS. 3 to 5 are used.
- step S10 at the start of the torque limiting process, the torque limiting coefficient calculation unit 61 acquires the motor temperature value Tm from the sensor 50 that detects the motor temperature.
- step S20 it is determined whether or not the motor temperature value Tm acquired from step S10 exceeds 0 ° C. If the motor temperature value Tm exceeds 0 ° C., the process proceeds to step S40, and if it is 0 ° C. or less, the process proceeds to step S30.
- step S30 it is determined that the torque limit is unnecessary, the torque limit coefficient is calculated as 100%, and the process proceeds to step S90.
- step S40 the motor temperature change rate ⁇ Tm is calculated from the deviation between the previous motor temperature value Tmz and the motor temperature value Tm.
- step S50 it is determined whether or not the motor temperature change rate ⁇ Tm calculated in step S40 exceeds a predetermined value. If the motor temperature change rate ⁇ Tm exceeds the predetermined value, the process proceeds to step S70, and if it is equal to or less than the predetermined value, the process proceeds to step S60.
- step S60 the torque limit coefficient Lmt is calculated from the initial value torque command coefficient map, and the process proceeds to step S90.
- step S70 the slope of the torque limit coefficient map is newly generated from the motor temperature change rate ⁇ Tm.
- FIG. 3 is a torque limit coefficient map. Note that FIG. 3A is a conventional torque limit coefficient map, and FIG. 3B is a torque limit coefficient map of the present invention.
- step S50 When the motor temperature change rate ⁇ Tm exceeds a predetermined value in step S50, the torque is limited as shown in FIG. 3B in the section of the motor temperature T1 to T2 of a certain constant value based on the motor temperature change rate ⁇ Tm. Change the slope of the coefficient map. Specifically, the torque limit coefficient map is set in the horizontal direction so that the torque limit value at T1 and T2 becomes closer as ⁇ Tm becomes larger, with the torque limit coefficient at T3, which is the intermediate temperature between the motor temperatures T1 and T2, as the fulcrum. Tilt to.
- step S80 the torque limit coefficient Lmt corresponding to the motor temperature value Tm is calculated from the torque limit coefficient map after the inclination is changed calculated in step S70.
- step S90 the torque limit coefficient Lmt calculated in step S30, step S60, or step S80 is multiplied by the torque command Trq acquired from the host controller to calculate the torque command Trq * after the limit, and the flowchart ends.
- the torque limiting unit calculates a limited torque command based on the motor temperature and limits the output torque of the motor.
- FIG. 4 is a diagram showing the contents of torque limitation during motor heating in the conventional method
- FIG. 5 is a diagram showing the transition of the inclination of the torque limiting coefficient map according to the present invention.
- Torque is limited from the first temperature limit T1 (time t1 on the horizontal axis) in FIG. 4, but due to the delay in conversion from current to heat generation and the delay in detecting the motor temperature value Tm, the control device 60 with respect to the motor temperature value Tm There is a delay in the reaction. Therefore, at the time t2, a phenomenon occurs in which the torque after limitation temporarily drops to Trq * 2 as shown in FIG. After that, while hunting the limit torque, at the time point t3 in FIG. 4, a point is formed that balances with the motor temperature value Tm at a predetermined post-limit torque value (continuous rated value), and the graph converges.
- the continuous rated value changes depending on the operating conditions such as the motor rotation speed, the atmospheric temperature, and the state of the cooling device.
- the upper graph of FIG. 5 is a graph of the motor temperature value Tm similar to that of FIG.
- the graphs at the bottom of FIG. 5 are a graph showing the time change rate of the motor temperature (hereinafter referred to as the temperature change rate ⁇ TCm) and a graph showing the slope of the torque limit coefficient map, respectively, with the time t as the horizontal axis.
- variable rate of the inclination of the torque limit coefficient map according to the embodiment of the present invention is determined based on the motor temperature change rate ⁇ TCm.
- the first temperature change rate is ⁇ TCm1.
- the temperature change rate ⁇ TCm becomes high by the time t1 when the torque limitation is started, as shown in the graph in the middle of FIG.
- the slope of the torque limit coefficient map is made small (horizontally). This corresponds to the change in the inclination of the torque limit coefficient map in FIG. 3 in the horizontal direction.
- the slope of the torque limit coefficient map can be changed within the range from the first slope S1 to the second slope S2, and the variable angle is limited.
- the slope of the torque limiting coefficient map changes within the variable range R of FIG. 3 (b).
- the slope of the torque limit coefficient map is the lower limit S1.
- the temperature change rate ⁇ TCm becomes 0 when the motor temperature value Tm reaches the highest point. From here, since the motor temperature value Tm starts to decrease, the temperature change rate ⁇ TCm rises again, and when the first temperature change rate ⁇ TCm1 is exceeded, the inclination of the torque limit coefficient map is reduced again.
- a temporary delay filter is added to multiply the deviation between the first temperature change rate ⁇ TCm1 and the motor temperature value Tm by a predetermined gain and suppress an excessive slope change. It was done.
- the torque of the torque limiting unit changes more slowly than when the time change rate of the motor temperature is equal to or less than the predetermined value. Limit the torque so that it does. Further, the torque limit amount is made variable by changing the inclination of the torque limit coefficient map, which is a relational expression between the motor temperature and the torque limit rate. Further, when the rate of change of the motor temperature is large, the inclination of the relational expression between the motor temperature and the torque limit rate can be reduced, and the current flowing through the motor so that the torque changes gently with the change of the motor temperature. To limit.
- the control device 60 limits the control device 60 to the PWM generation unit 63 that outputs a PWM drive signal to the inverter 40, and the PWM generation unit 63 based on the torque command from the upper control unit and the motor temperature.
- the torque limiting unit includes a torque limiting unit that outputs a rear torque command, and the torque limiting unit includes a torque limiting coefficient calculating unit 61 that calculates a torque limiting coefficient based on the motor temperature, and the torque command from the upper control unit.
- the post-restriction torque calculation unit 62 that outputs the post-restriction torque command to the PWM generation unit 63 based on the torque limit coefficient output from the torque limit coefficient calculation unit 61, and the torque limit coefficient
- the calculation unit 61 limits the output torque of the motor 30 based on the motor temperature when the motor temperature is higher than the predetermined temperature, and when the time change rate of the motor temperature is larger than the predetermined value, the calculation unit 61 limits the output torque.
- the torque is limited so that the torque changes more slowly than when the rate of change of the motor temperature with time is equal to or less than the predetermined value. Since this is done, the output of the motor does not drop more than necessary, and the motor can be protected.
- the torque limit coefficient calculation unit 61 of the control device 60 changes the torque limit amount by changing the inclination of the relational expression between the motor temperature and the torque limit rate. Since this is done, hunting can be suppressed according to the rate of change in the motor temperature.
- the torque limit coefficient calculation unit 61 of the control device 60 reduces the inclination of the relational expression between the motor temperature and the torque limit rate as the rate of change in the motor temperature increases. As a result, hunting can be suppressed without excessive torque limitation even in a transient state in which the motor temperature begins to rise sharply.
- the torque limiting unit of the control device 60 limits the current flowing through the motor 30 so that the torque changes gently with respect to the change in the motor temperature. Since this is done, the output of the vehicle does not change and the performance does not deteriorate.
- FIG. 6 is a diagram showing a configuration of a control device 60A showing a second embodiment of the present invention.
- the control device 60A adds a motor temperature compensation unit 64 to the control device 60 described with reference to FIG.
- the motor temperature value Tm is input by the torque limit coefficient calculation unit 61, but as shown in FIG. 6, the motor temperature estimated value TmA in which the detection delay and the detection error of the motor temperature value Tm are corrected is obtained. Generated and input by the motor temperature correction unit 64.
- the motor temperature detected by the control device 60 is a temperature corrected so as to approach the actual motor temperature with respect to the temperature detected by the sensor 50. Since this is done, hunting at the time of torque limitation can be further reduced.
- FIG. 7 is a torque limiting coefficient map of the control device 60B showing the third embodiment of the present invention.
- the torque limit coefficient map of FIG. 7 is the torque limit coefficient map of FIG. 3 which is the first embodiment, and the intersection T3 between T1 and T2 is changed depending on the operating conditions, the cooling conditions, and the like. That is, the fulcrum when changing the inclination of the relational expression between the motor temperature and the torque limit rate is variable.
- FIG. 7 An example of FIG. 7 is given.
- the point at which the limiting torque saturates is closer to T2 than T3 as shown in FIG.
- the time for torque limiting within the region A in FIG. 7 increases, so that the torque temporarily exceeds the expected torque. May be output. Therefore, by setting the intersection T3 to a point closer to T2 than T1 like T3B, torque hunting can be reduced while suppressing an unexpected temperature rise.
- the torque limit coefficient calculation unit 61 of the control device 60 makes the fulcrum when changing the inclination of the relational expression between the motor temperature and the torque limit rate variable. Since this is done, torque hunting can be reduced while suppressing an unexpected temperature rise due to environmental conditions.
- the present invention has described the case where the above embodiment is applied to a system in which a three-phase AC motor is mounted as a load, but the present invention is not limited to this, and can be applied to a system provided with a rotating machine. Is.
- the present invention has described the torque limiting function related to the motor temperature of the motor control device, it can also be applied to the output limitation at the temperature for other heat generating parts.
- the inverter of the motor drive device has a temperature detection circuit and the inverter is protected by limiting the output to the input of the detected temperature, the conversion from current to heat is delayed. Therefore, the configuration of the present invention is provided. There is a possibility that torque hunting can be suppressed by adopting.
Landscapes
- Engineering & Computer Science (AREA)
- Power Engineering (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Control Of Ac Motors In General (AREA)
- Electric Propulsion And Braking For Vehicles (AREA)
- Control Of Electric Motors In General (AREA)
Abstract
Description
本発明の第1の実施形態に係る制御装置について図1~6を用いて説明する。図1は本発明の第1の実施形態を示す制御装置60の構成を表す図である。
本発明の第2の実施形態について図6を用いて説明する。図6は本発明の第2の実施形態を示す制御装置60Aの構成を表す図である。
本発明の第3の実施形態について図7を用いて説明する。図7は本発明の第3の実施形態を示す制御装置60Bのトルク制限係数マップである。
20 コンタクタ
30 交流モータ
40 インバータ
41 スイッチング素子
50 モータ温度センサ
60 制御装置
61 トルク制限係数算出部
62 制限後トルク算出部
63 PWM生成部
64 モータ温度補正部
Claims (6)
- インバータにPWM駆動信号を出力するPWM生成部と、
上位制御部からのトルク指令とモータ温度とに基づいて、前記PWM生成部に制限後トルク指令を出力するトルク制限部と、を備え、
前記トルク制限部は、
前記モータ温度に基づいてトルク制限係数を算出するトルク制限係数算出部と、
前記上位制御部からの前記トルク指令と、前記トルク制限係数算出部から出力される前記トルク制限係数に基づいて、前記PWM生成部に前記制限後トルク指令を出力する制限後トルク算出部と、を有し、
前記トルク制限係数算出部は、前記モータ温度が所定の温度よりも高い場合には、前記モータ温度に基づいてモータの出力トルクを制限し、前記モータ温度の時間変化率が所定値より大きい場合には、前記モータ温度の時間変化率が前記所定値以下の場合に比べて、トルクが緩やかに変化するように前記トルクを制限する制御装置。 - 請求項1に記載の制御装置であって、前記トルク制限係数算出部は、前記モータ温度とトルク制限率の関係式の傾きを変化させることで前記制限後トルク指令のトルク制限量を可変とする制御装置。
- 請求項2に記載の制御装置であって、前記トルク制限係数算出部は、前記モータ温度の変化率が大きいほど、前記モータ温度とトルク制限率の関係式の傾きを小さくする制御装置。
- 請求項1に記載の制御装置であって、前記モータ温度は、センサにより検出した温度に対して実際の前記モータ温度に近づくように補正された温度である制御装置。
- 請求項2に記載の制御装置であって、前記トルク制限係数算出部は、前記モータ温度とトルク制限率の関係式の傾きを変化させる際の支点を可変とする制御装置。
- 請求項1に記載の制御装置であって、前記トルク制限部は、前記モータ温度の変化に対して前記トルクが緩やかに変化するように、前記モータに流れる電流を制限する制御装置。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE112020005881.6T DE112020005881B4 (de) | 2020-01-28 | 2020-12-15 | Steuervorrichtung |
| JP2021574517A JP7303910B2 (ja) | 2020-01-28 | 2020-12-15 | 制御装置 |
| US17/795,720 US12409736B2 (en) | 2020-01-28 | 2020-12-15 | Motor control device using temperature determination |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2020011301 | 2020-01-28 | ||
| JP2020-011301 | 2020-01-28 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2021153050A1 true WO2021153050A1 (ja) | 2021-08-05 |
Family
ID=77078556
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/046664 Ceased WO2021153050A1 (ja) | 2020-01-28 | 2020-12-15 | 制御装置 |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12409736B2 (ja) |
| JP (1) | JP7303910B2 (ja) |
| DE (1) | DE112020005881B4 (ja) |
| WO (1) | WO2021153050A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025017781A1 (ja) * | 2023-07-14 | 2025-01-23 | 日立Astemo株式会社 | 制御装置 |
Families Citing this family (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US12409736B2 (en) * | 2020-01-28 | 2025-09-09 | Hitachi Astemo, Ltd. | Motor control device using temperature determination |
| CN114633628B (zh) * | 2022-03-21 | 2023-12-15 | 潍柴动力股份有限公司 | 一种过温保护方法、装置、电子设备及存储介质 |
| DE102023209803A1 (de) * | 2023-10-09 | 2025-04-10 | Robert Bosch Gesellschaft mit beschränkter Haftung | Verfahren und Vorrichtung zum Betreiben einer elektrischen Maschine, elektrische Maschine |
| CN117411389B (zh) * | 2023-12-14 | 2024-05-31 | 珠海格力电器股份有限公司 | 一种直流电机过热保护方法及直流电机 |
| CN117885549A (zh) * | 2023-12-27 | 2024-04-16 | 三一重机有限公司 | 故障控制方法、故障控制装置及工程机械 |
| CN118238629B (zh) * | 2024-03-22 | 2025-10-17 | 长沙中联重科环境产业有限公司 | 电机扭矩控制方法、装置、电动车辆及可读存储介质 |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003304604A (ja) * | 2002-04-09 | 2003-10-24 | Nissan Motor Co Ltd | モータ制御装置および方法 |
| WO2017163609A1 (ja) * | 2016-03-25 | 2017-09-28 | 株式会社デンソー | モータの制御装置 |
| JP2018102102A (ja) * | 2016-12-22 | 2018-06-28 | トヨタ自動車株式会社 | モータシステム |
| WO2018142952A1 (ja) * | 2017-02-02 | 2018-08-09 | 日立オートモティブシステムズ株式会社 | モータ制御装置 |
Family Cites Families (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2000032602A (ja) * | 1998-07-10 | 2000-01-28 | Toyota Motor Corp | モータ温度制御装置及び方法 |
| JP4211788B2 (ja) * | 2006-01-11 | 2009-01-21 | トヨタ自動車株式会社 | 電動機制御装置およびそれを備えた電動車両 |
| US12409736B2 (en) * | 2020-01-28 | 2025-09-09 | Hitachi Astemo, Ltd. | Motor control device using temperature determination |
-
2020
- 2020-12-15 US US17/795,720 patent/US12409736B2/en active Active
- 2020-12-15 JP JP2021574517A patent/JP7303910B2/ja active Active
- 2020-12-15 WO PCT/JP2020/046664 patent/WO2021153050A1/ja not_active Ceased
- 2020-12-15 DE DE112020005881.6T patent/DE112020005881B4/de active Active
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003304604A (ja) * | 2002-04-09 | 2003-10-24 | Nissan Motor Co Ltd | モータ制御装置および方法 |
| WO2017163609A1 (ja) * | 2016-03-25 | 2017-09-28 | 株式会社デンソー | モータの制御装置 |
| JP2018102102A (ja) * | 2016-12-22 | 2018-06-28 | トヨタ自動車株式会社 | モータシステム |
| WO2018142952A1 (ja) * | 2017-02-02 | 2018-08-09 | 日立オートモティブシステムズ株式会社 | モータ制御装置 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025017781A1 (ja) * | 2023-07-14 | 2025-01-23 | 日立Astemo株式会社 | 制御装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| US20230068986A1 (en) | 2023-03-02 |
| US12409736B2 (en) | 2025-09-09 |
| DE112020005881T5 (de) | 2022-09-15 |
| JP7303910B2 (ja) | 2023-07-05 |
| JPWO2021153050A1 (ja) | 2021-08-05 |
| DE112020005881B4 (de) | 2025-08-07 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7303910B2 (ja) | 制御装置 | |
| US8022650B2 (en) | Control apparatus of electric motor | |
| JP4706324B2 (ja) | モータ駆動システムの制御装置 | |
| CN102171922B (zh) | 交流电动机的控制装置和控制方法 | |
| US11104374B2 (en) | Motor control device, electrically driven actuator product, and electrically driven power steering device | |
| US11183964B2 (en) | Control device for an AC rotating electric machine | |
| JP3598975B2 (ja) | 燃料電池自動車の制御装置 | |
| CN111200144B (zh) | 电流控制系统、燃料电池系统以及升压转换器的控制方法 | |
| US9935567B2 (en) | Rotating electric machine control device | |
| WO2011039794A1 (ja) | 電力変換装置 | |
| JP7163150B2 (ja) | モータ制御装置 | |
| JP2006141095A (ja) | 永久磁石型同期モータを駆動制御する装置 | |
| CN111277182B (zh) | 一种车用永磁同步电机深度弱磁系统及其控制方法 | |
| JP6658576B2 (ja) | インバータ制御装置 | |
| JP4140241B2 (ja) | モータの駆動制御装置、駆動制御方法およびその方法を実現するプログラムを記録した記録媒体 | |
| JP2024129640A (ja) | 巻線界磁型モータの制御方法、及び、巻線界磁型モータの制御装置 | |
| CN120435819A (zh) | 马达控制装置及电动车 | |
| JP7238424B2 (ja) | 電動機駆動装置 | |
| EP2165409B1 (en) | System and method for limiting input voltage to a power delivery system having regeneration capability | |
| CN109586646B (zh) | 一种永磁同步电机角度误差自适应的方法 | |
| JP2009077606A (ja) | 発電機と電動機の関連制御装置 | |
| JP4123335B2 (ja) | 誘導電動機の速度センサレス制御装置 | |
| JP3622410B2 (ja) | インバータによる電動機の制御方法 | |
| JP2005086919A (ja) | 負荷駆動装置およびそれにおける制御をコンピュータに実行させるためのプログラムを記録したコンピュータ読取り可能な記録媒体 | |
| JP7735812B2 (ja) | 電動機制御方法、及び、電動機制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20916350 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2021574517 Country of ref document: JP Kind code of ref document: A |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20916350 Country of ref document: EP Kind code of ref document: A1 |
|
| WWG | Wipo information: grant in national office |
Ref document number: 112020005881 Country of ref document: DE |
|
| WWG | Wipo information: grant in national office |
Ref document number: 17795720 Country of ref document: US |