JP2016103221A - 予測進路推定装置 - Google Patents
予測進路推定装置 Download PDFInfo
- Publication number
- JP2016103221A JP2016103221A JP2014242231A JP2014242231A JP2016103221A JP 2016103221 A JP2016103221 A JP 2016103221A JP 2014242231 A JP2014242231 A JP 2014242231A JP 2014242231 A JP2014242231 A JP 2014242231A JP 2016103221 A JP2016103221 A JP 2016103221A
- Authority
- JP
- Japan
- Prior art keywords
- vehicle
- host vehicle
- filter
- predicted course
- frequency component
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images
Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60R—VEHICLES, VEHICLE FITTINGS, OR VEHICLE PARTS, NOT OTHERWISE PROVIDED FOR
- B60R21/00—Arrangements or fittings on vehicles for protecting or preventing injuries to occupants or pedestrians in case of accidents or other traffic risks
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/02—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to ambient conditions
- B60W40/06—Road conditions
- B60W40/072—Curvature of the road
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/10—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to vehicle motion
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06V—IMAGE OR VIDEO RECOGNITION OR UNDERSTANDING
- G06V20/00—Scenes; Scene-specific elements
- G06V20/50—Context or environment of the image
- G06V20/56—Context or environment of the image exterior to a vehicle by using sensors mounted on the vehicle
-
- G—PHYSICS
- G07—CHECKING-DEVICES
- G07C—TIME OR ATTENDANCE REGISTERS; REGISTERING OR INDICATING THE WORKING OF MACHINES; GENERATING RANDOM NUMBERS; VOTING OR LOTTERY APPARATUS; ARRANGEMENTS, SYSTEMS OR APPARATUS FOR CHECKING NOT PROVIDED FOR ELSEWHERE
- G07C5/00—Registering or indicating the working of vehicles
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W2050/0001—Details of the control system
- B60W2050/0043—Signal treatments, identification of variables or parameters, parameter estimation or state estimation
- B60W2050/0052—Filtering, filters
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/932—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles using own vehicle data, e.g. ground speed, steering wheel direction
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/9325—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles for inter-vehicle distance regulation, e.g. navigating in platoons
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06V—IMAGE OR VIDEO RECOGNITION OR UNDERSTANDING
- G06V20/00—Scenes; Scene-specific elements
- G06V20/50—Context or environment of the image
- G06V20/56—Context or environment of the image exterior to a vehicle by using sensors mounted on the vehicle
- G06V20/588—Recognition of the road, e.g. of lane markings; Recognition of the vehicle driving pattern in relation to the road
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Mechanical Engineering (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Transportation (AREA)
- Mathematical Physics (AREA)
- Computer Networks & Wireless Communication (AREA)
- Electromagnetism (AREA)
- Aviation & Aerospace Engineering (AREA)
- Multimedia (AREA)
- Theoretical Computer Science (AREA)
- Traffic Control Systems (AREA)
- Control Of Driving Devices And Active Controlling Of Vehicle (AREA)
- Navigation (AREA)
Abstract
Description
ここで、Yはヨーレートセンサ12によるヨーレートの検出値(以下、実ヨーレート)である。2πfはアナログフィルタであり、fはカットオフ周波数である。Y0はフィルタ処理後のヨーレート(以下、演算ヨーレート)である。
算出された予測進路の推定値Rは、車間距離制御部22による車間制御に使用されることとなる。
Claims (9)
- 自車両の予測進路を推定する予測進路推定装置(20)であって、
自車両の旋回データを取得する旋回データ取得手段と、
前記旋回データ取得手段により取得した旋回データに含まれる高周波成分を除去するフィルタ手段と、
前記フィルタ手段のフィルタ処理後の旋回データと自車両の車速とに基づいて、自車両の進路予測を実施する予測手段と、
自車両が道路の形状切り替わり部分を走行することを判定する判定手段と、
自車両が道路の形状切り替わり部分を走行すると判定された場合に、前記フィルタ手段において前記高周波成分が除去される度合いを変更する特性変更手段と、
を備えることを特徴とする予測進路推定装置。 - 前記特性変更手段は、前記フィルタ手段のフィルタ特性を前記高周波成分が除去されやすい側に変更する場合には、前記高周波成分が除去されにくくする側に変更する場合に比べて、前記高周波成分が除去される度合いの変更を緩やかに実施する請求項1に記載の予測進路推定装置。
- 車両の車線変更の有無を検出する車線変更検出手段を備え、
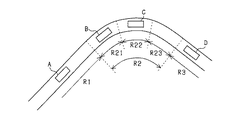
前記特性変更手段は、前記車線変更がある場合には、自車両が道路切り替わり部分を走行するとの判定結果に関わらず、前記高周波成分が除去される度合いを変更しない請求項1又は2に記載の予測進路推定装置。 - 前記特性変更手段は、自車両が道路のカーブの入り口部分又はカーブの出口部分を走行する場合に、前記高周波成分が除去されにくくする側に前記フィルタ手段のフィルタ特性を変更する請求項1乃至3のいずれか1項に記載の予測進路推定装置。
- 前記特性変更手段は、自車両が、曲率変化を伴う曲率変化部分と曲率が一定となる曲率一定部分とを有するカーブを走行する場合に、前記曲率変化部分では、前記曲率一定部分よりも、前記高周波成分が除去されにくくする側に前記フィルタ手段のフィルタ特性を変更する請求項1乃至4のいずれか1項に記載の予測進路推定装置。
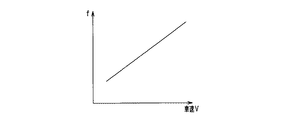
- 自車両の車速を検出する車速検出手段を備え、
前記特性変更手段は、前記車速に応じて高周波成分を除去される度合いを変更する請求項1乃至5のいずれか1項に記載の予測進路推定装置。 - 前記特性変更手段は、自車両が走行する道路の曲率に応じて、前記高周波成分が除去される度合いを変更する請求項1乃至6のいずれか1項に記載の予測進路推定装置。
- 前記旋回データは、自車両のヨーレート又は操舵角の検出値である請求項1乃至7のいずれか1項に記載の予測進路推定装置。
- 自車両に設けられてその前方に位置する物体を検出する物体検出手段と、
前記物体が先行車両である場合に、自車両の加速と減速を制御して、先行車に対して車間距離を維持して追従走行する追従走行制御手段と、を備える請求項1乃至8のいずれか1項に記載の予測進路推定装置。
Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2014242231A JP6356584B2 (ja) | 2014-11-28 | 2014-11-28 | 予測進路推定装置 |
| CN201580063809.1A CN107004365B (zh) | 2014-11-28 | 2015-10-13 | 预测进路推断装置以及预测进路推断方法 |
| DE112015005330.1T DE112015005330B4 (de) | 2014-11-28 | 2015-10-13 | Vorhersagekursabschätzvorrichtung und Vorhersagekursabschätzverfahren |
| PCT/JP2015/078898 WO2016084501A1 (ja) | 2014-11-28 | 2015-10-13 | 予測進路推定装置及び予測進路推定方法 |
| US15/529,914 US10423161B2 (en) | 2014-11-28 | 2015-10-13 | Predicted course estimating apparatus and predicted course estimating method |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2014242231A JP6356584B2 (ja) | 2014-11-28 | 2014-11-28 | 予測進路推定装置 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2016103221A true JP2016103221A (ja) | 2016-06-02 |
| JP6356584B2 JP6356584B2 (ja) | 2018-07-11 |
Family
ID=56074079
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2014242231A Active JP6356584B2 (ja) | 2014-11-28 | 2014-11-28 | 予測進路推定装置 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US10423161B2 (ja) |
| JP (1) | JP6356584B2 (ja) |
| CN (1) | CN107004365B (ja) |
| DE (1) | DE112015005330B4 (ja) |
| WO (1) | WO2016084501A1 (ja) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2017072996A (ja) * | 2015-10-07 | 2017-04-13 | 株式会社日本自動車部品総合研究所 | 道路曲率計測装置 |
| WO2018056207A1 (ja) * | 2016-09-23 | 2018-03-29 | 日立オートモティブシステムズ株式会社 | 車両制御装置及び車両制御方法 |
| CN114670851A (zh) * | 2022-04-20 | 2022-06-28 | 北京理工大学重庆创新中心 | 基于寻优跟踪算法的辅助驾驶系统、方法、终端及介质 |
Families Citing this family (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US10752257B2 (en) * | 2016-02-19 | 2020-08-25 | A Truly Electric Car Company | Car operating system that controls the car's direction and speed |
| JP6780611B2 (ja) | 2017-08-25 | 2020-11-04 | トヨタ自動車株式会社 | 自動運転装置 |
| JP6897495B2 (ja) | 2017-10-27 | 2021-06-30 | トヨタ自動車株式会社 | 配車システム及び配車方法 |
| WO2019104581A1 (zh) * | 2017-11-30 | 2019-06-06 | 深圳市大疆创新科技有限公司 | 轨迹生成方法、装置和无人驾驶地面车辆 |
| JP7205154B2 (ja) | 2018-10-16 | 2023-01-17 | トヨタ自動車株式会社 | 表示装置 |
| JP7183769B2 (ja) * | 2018-12-20 | 2022-12-06 | 株式会社デンソー | 運転支援装置 |
| US11851844B2 (en) * | 2020-01-21 | 2023-12-26 | Caterpillar Inc. | Implement travel prediction for a work machine |
| DE112020007222T5 (de) * | 2020-05-21 | 2023-04-06 | Mitsubishi Electric Corporation | Fahrweg-erzeugungsvorrichtung und fahrweg-erzeugungsverfahren |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2004066912A (ja) * | 2002-08-05 | 2004-03-04 | Nissan Motor Co Ltd | 車両用障害物検知装置 |
| WO2005020183A1 (ja) * | 2003-08-20 | 2005-03-03 | Hitachi, Ltd. | 先行車選択装置及び先行車選択方法 |
| JP2006341739A (ja) * | 2005-06-09 | 2006-12-21 | Nissan Motor Co Ltd | 車線推定装置 |
| JP2008162492A (ja) * | 2006-12-28 | 2008-07-17 | Nissan Diesel Motor Co Ltd | 車載用レーダ装置 |
| JP2014191596A (ja) * | 2013-03-27 | 2014-10-06 | Nippon Soken Inc | 車載装置 |
Family Cites Families (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP4300272B2 (ja) * | 2001-09-10 | 2009-07-22 | Nsc株式会社 | デジタルフィルタおよびその設計方法 |
| DE10218924A1 (de) | 2002-04-27 | 2003-11-06 | Bosch Gmbh Robert | Verfahren und Vorrichtung zur Kursprädiktion bei Kraftfahrzeugen |
| DE10254394A1 (de) * | 2002-11-21 | 2004-06-03 | Lucas Automotive Gmbh | System zur Beeinflussung der Geschwindigkeit eines Kraftfahrzeuges |
| JP4302612B2 (ja) | 2004-10-26 | 2009-07-29 | 本田技研工業株式会社 | 車両の走行安全装置 |
| JP4654796B2 (ja) | 2005-06-29 | 2011-03-23 | トヨタ自動車株式会社 | 車両用運転支援装置 |
| JP4849072B2 (ja) * | 2005-12-21 | 2011-12-28 | トヨタ自動車株式会社 | 内燃機関の失火判定装置およびこれを搭載する車両並びに失火判定方法 |
| JP4985142B2 (ja) * | 2007-06-26 | 2012-07-25 | 株式会社日本自動車部品総合研究所 | 画像認識装置および画像認識装置の画像認識処理方法 |
| DE102011084069A1 (de) * | 2011-10-06 | 2013-04-11 | Continental Teves Ag & Co. Ohg | Verfahren zur Bestimmung eines Modell-Vordrucks mittels eines mathematischen Modells in einem elektronisch geregelten Kraftfahrzeugbremssystem |
-
2014
- 2014-11-28 JP JP2014242231A patent/JP6356584B2/ja active Active
-
2015
- 2015-10-13 WO PCT/JP2015/078898 patent/WO2016084501A1/ja not_active Ceased
- 2015-10-13 DE DE112015005330.1T patent/DE112015005330B4/de active Active
- 2015-10-13 US US15/529,914 patent/US10423161B2/en active Active
- 2015-10-13 CN CN201580063809.1A patent/CN107004365B/zh active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2004066912A (ja) * | 2002-08-05 | 2004-03-04 | Nissan Motor Co Ltd | 車両用障害物検知装置 |
| WO2005020183A1 (ja) * | 2003-08-20 | 2005-03-03 | Hitachi, Ltd. | 先行車選択装置及び先行車選択方法 |
| JP2006341739A (ja) * | 2005-06-09 | 2006-12-21 | Nissan Motor Co Ltd | 車線推定装置 |
| JP2008162492A (ja) * | 2006-12-28 | 2008-07-17 | Nissan Diesel Motor Co Ltd | 車載用レーダ装置 |
| JP2014191596A (ja) * | 2013-03-27 | 2014-10-06 | Nippon Soken Inc | 車載装置 |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2017072996A (ja) * | 2015-10-07 | 2017-04-13 | 株式会社日本自動車部品総合研究所 | 道路曲率計測装置 |
| WO2018056207A1 (ja) * | 2016-09-23 | 2018-03-29 | 日立オートモティブシステムズ株式会社 | 車両制御装置及び車両制御方法 |
| CN114670851A (zh) * | 2022-04-20 | 2022-06-28 | 北京理工大学重庆创新中心 | 基于寻优跟踪算法的辅助驾驶系统、方法、终端及介质 |
Also Published As
| Publication number | Publication date |
|---|---|
| CN107004365A (zh) | 2017-08-01 |
| DE112015005330B4 (de) | 2025-10-30 |
| JP6356584B2 (ja) | 2018-07-11 |
| US20170364084A1 (en) | 2017-12-21 |
| DE112015005330T8 (de) | 2017-09-21 |
| WO2016084501A1 (ja) | 2016-06-02 |
| US10423161B2 (en) | 2019-09-24 |
| DE112015005330T5 (de) | 2017-08-17 |
| CN107004365B (zh) | 2020-06-16 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6356584B2 (ja) | 予測進路推定装置 | |
| JP6158523B2 (ja) | 車間距離制御装置 | |
| JP6183388B2 (ja) | 車両用制御装置 | |
| KR101946043B1 (ko) | 차량 탑재 장치의 호스트 차량의 운행 경로에 배치된 선행 차량을 선택하는 차량 탑재 장치 | |
| WO2019008647A1 (ja) | 運転支援車両の目標車速生成方法及び目標車速生成装置 | |
| JP2018002083A (ja) | 車両制御装置 | |
| US9409575B2 (en) | Vehicle control device | |
| WO2018101208A1 (ja) | 走行制御装置 | |
| CN107004366A (zh) | 车辆控制装置以及车辆控制方法 | |
| JP5947279B2 (ja) | 進路推定装置,及びプログラム | |
| JP2010137803A (ja) | 車両用運転支援装置 | |
| JP6481627B2 (ja) | 車両用走行制御装置 | |
| JP2006088771A (ja) | 走行制御装置 | |
| JP2019038363A (ja) | 車両用走行制御装置 | |
| JP5994757B2 (ja) | 車両の制御装置 | |
| JP2009149167A (ja) | 車両の走行制御装置。 | |
| JP4204830B2 (ja) | 車両用運転支援装置 | |
| JP4824511B2 (ja) | 車両の走行安全装置 | |
| JP4946212B2 (ja) | 走行支援装置 | |
| JP4407315B2 (ja) | ターゲット推定装置 | |
| JP2006298254A (ja) | 走行支援装置 | |
| JP6881190B2 (ja) | 運転支援装置 | |
| JP4622414B2 (ja) | 走行制御装置 | |
| JP2016103226A (ja) | 予測進路推定装置 | |
| JP5824964B2 (ja) | 車両走行制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20170608 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20180306 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20180423 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20180522 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20180614 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 6356584 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |