CN114770263A - Efficient automatic polishing machine device - Google Patents
Efficient automatic polishing machine device Download PDFInfo
- Publication number
- CN114770263A CN114770263A CN202210475772.5A CN202210475772A CN114770263A CN 114770263 A CN114770263 A CN 114770263A CN 202210475772 A CN202210475772 A CN 202210475772A CN 114770263 A CN114770263 A CN 114770263A
- Authority
- CN
- China
- Prior art keywords
- blanking
- plate
- workpiece
- axis
- module
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images







Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B7/00—Machines or devices designed for grinding plane surfaces on work, including polishing plane glass surfaces; Accessories therefor
- B24B7/20—Machines or devices designed for grinding plane surfaces on work, including polishing plane glass surfaces; Accessories therefor characterised by a special design with respect to properties of the material of non-metallic articles to be ground
- B24B7/22—Machines or devices designed for grinding plane surfaces on work, including polishing plane glass surfaces; Accessories therefor characterised by a special design with respect to properties of the material of non-metallic articles to be ground for grinding inorganic material, e.g. stone, ceramics, porcelain
- B24B7/24—Machines or devices designed for grinding plane surfaces on work, including polishing plane glass surfaces; Accessories therefor characterised by a special design with respect to properties of the material of non-metallic articles to be ground for grinding inorganic material, e.g. stone, ceramics, porcelain for grinding or polishing glass
- B24B7/242—Machines or devices designed for grinding plane surfaces on work, including polishing plane glass surfaces; Accessories therefor characterised by a special design with respect to properties of the material of non-metallic articles to be ground for grinding inorganic material, e.g. stone, ceramics, porcelain for grinding or polishing glass for plate glass
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B41/00—Component parts such as frames, beds, carriages, headstocks
- B24B41/005—Feeding or manipulating devices specially adapted to grinding machines
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B41/00—Component parts such as frames, beds, carriages, headstocks
- B24B41/02—Frames; Beds; Carriages
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Ceramic Engineering (AREA)
- Inorganic Chemistry (AREA)
- Constituent Portions Of Griding Lathes, Driving, Sensing And Control (AREA)
Abstract
本发明提供了一种高效自动抛光机装置,涉及自动化设备技术领域;包括分片上料机构、支撑底座、中转流水线、上下料机械手、工件加工机构以及分片下料机构;所述分片上料机构和分片下料机构分别位于支撑底座的两侧,所述的中转流水线从支撑底座上穿过,中转流水线的两端分别位于分片上料机构和分片下料机构内部;所述的上下料机械手和工件加工机构均设置于支撑底座上,且上下料机械手位于中转流水线的上方;本发明的有益效果是:能够实现玻璃工件的全自动化加工以及自动上下料,极大的提高了加工效率的同时节约了人力和成本。

The invention provides a high-efficiency automatic polishing machine device, which relates to the technical field of automation equipment. and the slicing and unloading mechanism are respectively located on both sides of the support base, the transfer assembly line passes through the support base, and the two ends of the transfer assembly line are respectively located inside the slicing feeding mechanism and the slicing and unloading mechanism; Both the manipulator and the workpiece processing mechanism are arranged on the support base, and the loading and unloading manipulator is located above the transfer assembly line; the beneficial effects of the present invention are: fully automatic processing and automatic loading and unloading of glass workpieces can be realized, which greatly improves the processing efficiency. At the same time save manpower and cost.
Description
技术领域technical field
本发明涉及自动化设备技术领域,更具体的说,本发明涉及一种高效自动抛光机装置。The invention relates to the technical field of automation equipment, and more specifically, the invention relates to a high-efficiency automatic polishing machine device.
背景技术Background technique
目前市场上对抛光机的需求持续上涨,针对智能穿戴盖板、玻璃面板等玻璃材质进行抛光时,为了同时对多片玻璃进行抛光以提高抛光效率,现有市场大都采用人员手工分片并采用多片玻璃叠放在一起,通过控制治具对玻璃进行上下固定,操作人员将治具置于抛光设备上之后,抛光设备上的抛光轮从治具两侧同时对多片玻璃的边沿接触,从而同时对多片玻璃进行抛光;该操作方法会出现烧边,抛光不均匀等现象,抛光质量不能得到保证,抛光完成后再通过人员操作逐片拿取,将玻璃分开,再通过操作人员将已加工玻璃工件放入指定料框,这种人工操作效率较底,人工成本高且存在安全隐患,抛光的产品质量得不到保证,已无法满足现有市场的需求。At present, the demand for polishing machines in the market continues to rise. When polishing glass materials such as smart wearable cover plates and glass panels, in order to polish multiple pieces of glass at the same time to improve polishing efficiency, most of the existing markets use manual segmentation by personnel and use Multiple pieces of glass are stacked together, and the glass is fixed up and down by controlling the jig. After the operator places the jig on the polishing equipment, the polishing wheel on the polishing equipment touches the edges of the multiple pieces of glass from both sides of the jig at the same time. Therefore, multiple pieces of glass are polished at the same time; this operation method will cause edge burning, uneven polishing, etc., and the polishing quality cannot be guaranteed. The processed glass workpiece is put into the designated material frame. This kind of manual operation has low efficiency, high labor cost and hidden safety hazards. The quality of the polished product cannot be guaranteed, and it can no longer meet the needs of the existing market.
发明内容SUMMARY OF THE INVENTION
为了克服现有技术的不足,本发明提供一种高效自动抛光机装置,能够实现玻璃工件的自动抛光加工以及工件的自动下料,提高加工效率,同时避免人工下料易造成工伤事故等问题。In order to overcome the deficiencies of the prior art, the present invention provides a high-efficiency automatic polishing machine device, which can realize automatic polishing processing of glass workpieces and automatic blanking of workpieces, improve processing efficiency, and avoid problems such as work-related accidents caused by manual blanking.
本发明解决其技术问题所采用的技术方案是:一种高效自动抛光机装置,其改进之处在于,包括分片上料机构、支撑底座、中转流水线、上下料机械手、工件加工机构以及分片下料机构;The technical scheme adopted by the present invention to solve the technical problem is: a high-efficiency automatic polishing machine device. material agency;
所述分片上料机构和分片下料机构分别位于支撑底座的两侧,所述的中转流水线从支撑底座上穿过,中转流水线的两端分别位于分片上料机构和分片下料机构内部;The slice feeding mechanism and the slice unloading mechanism are respectively located on both sides of the support base, the transfer assembly line passes through the support base, and the two ends of the transfer assembly line are respectively located inside the slice feed mechanism and the slice unloading mechanism. ;
所述的上下料机械手和工件加工机构均设置于支撑底座上,且上下料机械手位于中转流水线的上方,上下料机械手用于将待加工的工件从流水线转移至工件加工机构内,并将已加工完成的工件从工件加工机构上转移至中转流水线。The loading and unloading manipulator and the workpiece processing mechanism are both arranged on the support base, and the loading and unloading manipulator is located above the transfer assembly line. The loading and unloading manipulator is used to transfer the workpiece to be processed from the assembly line to the workpiece processing mechanism. The completed workpiece is transferred from the workpiece processing mechanism to the transfer line.
在上述的结构中,所述的工件加工机构包括加工治具、X轴运动模组、Y轴运动模组、Z1轴运动模组以及Z2轴运动模组;In the above structure, the workpiece processing mechanism includes a processing fixture, an X-axis motion module, a Y-axis motion module, a Z1-axis motion module, and a Z2-axis motion module;
所述的Y轴运动模组设置于支撑底座上,加工治具设置于Y轴运动模组上,通过Y轴运动模组的驱动,使加工治具在Y轴方向往复运动;The Y-axis movement module is arranged on the support base, and the processing jig is arranged on the Y-axis movement module, and the processing jig is reciprocated in the Y-axis direction through the drive of the Y-axis movement module;
所述的X轴运动模组设置于加工治具的上方,Z1轴运动模组和Z2轴运动模组均设置于X轴运动模组上,且Z1轴运动模组和Z2轴运动模组均包括有对加工治具上的工件进行加工的抛光盘。The X-axis motion module is arranged above the processing jig, the Z1-axis motion module and the Z2-axis motion module are both arranged on the X-axis motion module, and both the Z1-axis motion module and the Z2-axis motion module are Including a polishing disc for processing the workpiece on the processing jig.
在上述的结构中,所述的Z1轴运动模组和Z2轴运动模组均包括有主轴拖板、主轴电机以及抛光轮;In the above structure, the Z1-axis motion module and the Z2-axis motion module both include a spindle carriage, a spindle motor and a polishing wheel;
所述的主轴电机固定于主轴拖板的侧壁上,抛光轮固定安装在主轴电机的电机轴顶端,所述的抛光盘安装于抛光轮下方。The spindle motor is fixed on the side wall of the spindle carriage, the polishing wheel is fixedly installed on the top of the motor shaft of the spindle motor, and the polishing disc is installed under the polishing wheel.
在上述的结构中,所述的支撑底座上设置有机身内罩,所述的加工治具位于机身内罩内部,机身内罩的底部设置有多个漏水孔。In the above structure, the support base is provided with an inner cover of the fuselage, the processing jig is located inside the inner cover of the fuselage, and the bottom of the inner cover of the fuselage is provided with a plurality of water leakage holes.
在上述的结构中,所述的分片下料机构包括下料平台、驱动模组以及下料驱动组件,所述的下料驱动组件位于工作平台的上方,所述驱动模组设置于下料平台上,该驱动模组用于驱动下料驱动组件在X轴和Z轴方向的移动;In the above structure, the slicing and blanking mechanism includes a blanking platform, a drive module and a blanking drive assembly, the blanking drive assembly is located above the working platform, and the drive module is arranged on the blanking On the platform, the drive module is used to drive the movement of the blanking drive assembly in the X-axis and Z-axis directions;
所述的下料驱动组件包括下料侧立板、推料组件以及工件旋转组件,所述的工件旋转组件包括旋转气缸、吸盘安装板以及设置于吸盘安装板上的多个吸盘,所述旋转气缸固定于下料侧立板的一侧,吸盘安装板与旋转气缸的气缸杆相连接,该吸盘安装板在旋转气缸的驱动下实现水平状态和竖直状态的切换;The blanking drive assembly includes a blanking side vertical plate, a pusher assembly and a workpiece rotating assembly. The workpiece rotating assembly includes a rotating cylinder, a suction cup mounting plate and a plurality of suction cups arranged on the suction cup mounting plate. The air cylinder is fixed on one side of the vertical plate on the unloading side, and the suction cup mounting plate is connected with the cylinder rod of the rotating cylinder, and the suction cup mounting plate realizes the switching between the horizontal state and the vertical state under the driving of the rotating cylinder;
所述的推料组件设置于下料侧立板上,并位于旋转气缸的上方,该推料组件用于实现吸盘上工件的下料。The pusher assembly is arranged on the vertical plate on the unloading side and above the rotary cylinder, and the pusher assembly is used to realize the unloading of the workpiece on the suction cup.
在上述的结构中,所述的下料驱动组件还包括工件限位组件,工件限位组件包括限位气缸、限位推板、左侧支撑板、左侧活动导板、右侧支撑板以及右侧活动导板;In the above structure, the blanking drive assembly further includes a workpiece limit assembly, and the workpiece limit assembly includes a limit cylinder, a limit push plate, a left support plate, a left movable guide plate, a right support plate and a right support plate. Side movable guide;
所述的左侧支撑板和右侧支撑板相对固定在下料侧立板上,所述限位气缸固定于下料侧立板上并位于左侧支撑板和右侧支撑板之间,限位推板固定于限位气缸的气缸杆顶端;The left support plate and the right support plate are relatively fixed on the unloading side vertical plate, and the limit cylinder is fixed on the unloading side vertical plate and located between the left support plate and the right support plate. The push plate is fixed on the top of the cylinder rod of the limit cylinder;
所述的左侧活动导板与限位推板固定连接,右侧活动导板固定在右侧支撑板上,左侧活动导板和右侧活动导板相对设置,并分别位于吸盘安装板的两侧,以用于实现对吸盘上工件的夹持。The left movable guide plate is fixedly connected with the limit push plate, the right movable guide plate is fixed on the right support plate, the left movable guide plate and the right movable guide plate are arranged oppositely, and are respectively located on both sides of the suction cup installation plate to It is used to realize the clamping of the workpiece on the suction cup.
在上述的结构中,所述左侧活动导板和右侧活动导板相对的侧壁上均设置有向内凹陷的条形槽。In the above structure, the opposite side walls of the left movable guide plate and the right movable guide plate are provided with inwardly recessed strip grooves.
在上述的结构中,所述限位气缸的气缸杆穿过于左侧支撑板,所述限位推板位于左侧支撑板的外侧,限位推板上固定安装有多个导杆,所述左侧支撑板上设置有对应数量的导套,导杆的一端插入导套内。In the above structure, the cylinder rod of the limit cylinder passes through the left support plate, the limit push plate is located on the outer side of the left support plate, and a plurality of guide rods are fixedly installed on the limit push plate. A corresponding number of guide sleeves are arranged on the left support plate, and one end of the guide rod is inserted into the guide sleeve.
在上述的结构中,所述分片下料机构还包括已加工玻璃料框,该已加工玻璃料框设置于工作平台上,并位于下料驱动组件下方。In the above structure, the slicing and unloading mechanism further includes a processed frit frame, and the processed frit frame is arranged on the working platform and located below the blanking drive assembly.
在上述的结构中,所述的驱动模组包括下料机构X轴运动模组、下料机构Z轴运动模组以及下料机构Y轴运动模组;In the above structure, the drive module includes an X-axis movement module of the blanking mechanism, a Z-axis movement module of the blanking mechanism, and a Y-axis movement module of the blanking mechanism;
所述的下料机构Y轴运动模组设置于下料平台上,所述的已加工玻璃料框安装于下料机构Y轴运动模组上,并通过Y轴运动模组的驱动在Y轴方向往复运动;The Y-axis movement module of the blanking mechanism is arranged on the blanking platform, and the processed glass frit frame is installed on the Y-axis movement module of the blanking mechanism, and is driven on the Y-axis by the Y-axis movement module. direction reciprocating movement;
所述的下料平台上固定安装有下料机构支架,所述下料机构X轴运动模组设置于下料机构支架上,所述下料机构Z轴运动模组安装于下料机构X轴运动模组上。A blanking mechanism bracket is fixedly installed on the blanking platform, the X-axis movement module of the blanking mechanism is arranged on the blanking mechanism bracket, and the Z-axis movement module of the blanking mechanism is installed on the X-axis of the blanking mechanism on the motion module.
本发明的有益效果是:本发明的一种高效自动抛光机装置,分片上料机构进行自动分片及自动上料动作,配备中转流水线对待加工玻璃及已加工玻璃的自动流转动作,配备分片下料机构进行独立的下料动作;能够实现玻璃工件的全自动化加工以及自动上下料,极大的提高了加工效率的同时节约了人力和成本。The beneficial effects of the present invention are as follows: a high-efficiency automatic polishing machine device of the present invention, the slicing and feeding mechanism performs automatic slicing and automatic feeding actions, is equipped with a transfer assembly line for automatic circulation of the glass to be processed and the processed glass, and is equipped with slicing. The blanking mechanism performs independent blanking actions; it can realize fully automatic processing and automatic loading and unloading of glass workpieces, which greatly improves the processing efficiency and saves manpower and costs.
附图说明Description of drawings
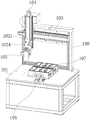
图1为本发明的一种高效自动抛光机装置的外部结构示意图。FIG. 1 is a schematic diagram of the external structure of a high-efficiency automatic polishing machine device of the present invention.
图2为本发明的一种高效自动抛光机装置的内部结构示意图。FIG. 2 is a schematic diagram of the internal structure of a high-efficiency automatic polishing machine device of the present invention.
图3为本发明的一种高效自动抛光机装置的俯视图。3 is a top view of a high-efficiency automatic polishing machine device of the present invention.
图4为本发明的一种高效自动抛光机装置的Z1轴运动模组的第一局部结构示意图。4 is a first partial structural schematic diagram of a Z1-axis motion module of a high-efficiency automatic polishing machine device of the present invention.
图5为本发明的一种高效自动抛光机装置的Z1轴运动模组的第二局部结构示意图。FIG. 5 is a second partial structural schematic diagram of a Z1-axis motion module of a high-efficiency automatic polishing machine device of the present invention.
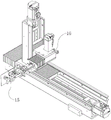
图6为本发明的分片下料机构的立体结构示意图。FIG. 6 is a schematic three-dimensional structure diagram of the slicing and blanking mechanism of the present invention.
图7为本发明的分片下料机构的下料驱动组件的结构示意图。FIG. 7 is a schematic structural diagram of the blanking drive assembly of the slice blanking mechanism of the present invention.
图8至图11为本发明的分片上料机构的结构示意图。8 to 11 are schematic structural diagrams of the slicing and feeding mechanism of the present invention.
具体实施方式Detailed ways
下面结合附图和实施例对本发明进一步说明。The present invention will be further described below in conjunction with the accompanying drawings and embodiments.
以下将结合实施例和附图对本发明的构思、具体结构及产生的技术效果进行清楚、完整地描述,以充分地理解本发明的目的、特征和效果。显然,所描述的实施例只是本发明的一部分实施例,而不是全部实施例,基于本发明的实施例,本领域的技术人员在不付出创造性劳动的前提下所获得的其他实施例,均属于本发明保护的范围。另外,专利中涉及到的所有联接/连接关系,并非单指构件直接相接,而是指可根据具体实施情况,通过添加或减少联接辅件,来组成更优的联接结构。本发明创造中的各个技术特征,在不互相矛盾冲突的前提下可以交互组合。The concept, specific structure and technical effects of the present invention will be clearly and completely described below with reference to the embodiments and accompanying drawings, so as to fully understand the purpose, characteristics and effects of the present invention. Obviously, the described embodiments are only a part of the embodiments of the present invention, rather than all the embodiments. Based on the embodiments of the present invention, other embodiments obtained by those skilled in the art without creative efforts are all within the scope of The scope of protection of the present invention. In addition, all the coupling/connection relationships involved in the patent do not mean that the components are directly connected, but refer to a better coupling structure by adding or reducing coupling accessories according to the specific implementation. Various technical features in the present invention can be combined interactively on the premise of not contradicting each other.
参照图1、图2以及图3所示,本发明揭示了一种高效自动抛光机装置,本实施例中,该装置包括分片上料机构20、支撑底座30、中转流水线40、上下料机械手50、工件加工机构60以及分片下料机构10;所述分片上料机构20和分片下料机构10分别位于支撑底座30的两侧,所述的中转流水线40从支撑底座30上穿过,中转流水线40的两端分别位于分片上料机构20和分片下料机构10内部;可以理解的是,分片上料机构20用于实现待加工玻璃工件的自动上料,将玻璃工件从料框中转移至中转流水线40上,分片下料机构10则用于实现已加工玻璃工件的自动下料,中转流水线40实现对玻璃工件的自动化传递;整个过程中无需人工参与。Referring to FIGS. 1 , 2 and 3 , the present invention discloses a high-efficiency automatic polishing machine device. In this embodiment, the device includes a
结合图2和图3所示,所述的上下料机械手50和工件加工机构60均设置于支撑底座30上,且上下料机械手50位于中转流水线40的上方,通过上下料机械手50将待加工的玻璃工件转移至工件加工机构60内,同时上下料机械手50还将已加工的玻璃工件从工件加工机构60中转移至中转流水线40上。另外,上下料机械手50与工件加工机构60之间还设置有定位机构70,在上下料机械手50进行玻璃工件的上料时,通过定位机构70实现玻璃工件的定位,以提高玻璃工件的加工精度。2 and 3, the loading and unloading
对于所述的工件加工机构60,参照图2及图3所示,工件加工机构60包括加工治具601、X轴运动模组602、Y轴运动模组603、Z1轴运动模组604以及Z2轴运动模组605,所述的Y轴运动模组603设置于支撑底座30上,加工治具601设置于Y轴运动模组603上,通过Y轴运动模组603的驱动,使加工治具601在Y轴方向往复运动;所述的X轴运动模组602设置于加工治具601的上方,Z1轴运动模组604和Z2轴运动模组605均设置于X轴运动模组602上,且Z1轴运动模组604和Z2轴运动模组605均包括有对加工治具601上的工件进行加工的抛光盘6041。For the
由于Z1轴运动模组604和Z2轴运动模组605的结构完全相同,参照图4、图5所示,以Z1轴运动模组604的结构为例,本发明提供了一具体实施例,所述的Z1轴运动模组604包括有主轴拖板6042、主轴电机6043以及抛光轮6044;所述的主轴电机6043固定于主轴拖板6042的侧壁上,抛光轮6044固定安装在主轴电机6043的电机轴顶端,所述的抛光盘6041安装于抛光轮6044下方,通过抛光盘6041实现对玻璃工件的打磨。本实施例中,主轴拖板6042上还安装有Z轴防护罩6045,主轴电机6043即位于Z轴防护罩6045内部;Z轴防护罩6045的下部安装有喷水头6046。Since the structures of the Z1-
另外,结合图2所示,所述的支撑底座30上设置有机身内罩301,所述的加工治具601位于机身内罩301内部,机身内罩301的底部设置有漏水孔,且漏水孔设置有网格状漏斗。结合图1、图2所示,支撑底座30上还设置有机身外罩302,该机身外罩302用于防水防尘防屑的同时,整体外观更整洁、美观、且能防止产品加工时污水外溅的问题。机身外罩302的一侧设置有测试透窗303,另一侧设置有系统柜304,机身外罩302的顶部还设置有信号灯305,机身外罩302的前方设置有推拉门306。In addition, as shown in FIG. 2 , the
在上述的实施例中,对于所述的分片下料机构10,本发明提供了一具体实施例,参照图6、图7所示,通过该分片下料机构10,实现已加工玻璃工件的自动化下料,本实施例中,分片下料机构10包括下料平台101、驱动模组以及下料驱动组件102,所述的下料驱动组件102位于工作平台的上方,所述驱动模组设置于下料平台101上,该驱动模组用于驱动下料驱动组件102在X轴和Z轴方向的移动;对于驱动模组,本实施例中,包括下料机构X轴运动模组103、下料机构Z轴运动模组104以及下料机构Y轴运动模组105,下料平台101上还设置有用于接收玻璃工件的已加工玻璃料框107,已加工玻璃料框107位于下料驱动组件102下方,便于实现玻璃工件106的接收。并且,所述的下料机构Y轴运动模组105设置于下料平台101上,所述的已加工玻璃料框107安装于下料机构Y轴运动模组105上,并通过Y轴运动模组的驱动在Y轴方向往复运动;所述的下料平台101上固定安装有下料机构支架108,所述下料机构X轴运动模组103设置于下料机构支架108上,所述下料机构Z轴运动模组104安装于下料机构X轴运动模组103上。In the above-mentioned embodiment, the present invention provides a specific embodiment for the described slicing and
参照图6所示,下料驱动组件102安装于下料机构Z轴运动模组104上,以通过下料机构Z轴运动模组104的驱动,使下料驱动组件102在Z轴方向往复运动。在本实施例中,下料机构X轴运动模组103、下料机构Z轴运动模组104以及下料机构Y轴运动模组105均采用电机丝杆模组,其结构在现有技术中属于非常成熟的技术方案,因此本实施例中则不再对下料机构X轴运动模组103、下料机构Z轴运动模组104以及下料机构Y轴运动模组105的详细结构进行说明。Referring to FIG. 6 , the blanking
对于所述的下料驱动组件102,结合图6和图7所示,本发明提供了一具体实施例,所述的下料驱动组件102包括下料侧立板1021、推料组件以及工件旋转组件,所述的工件旋转组件包括旋转气缸1022、吸盘安装板1023以及设置于吸盘安装板1023上的多个吸盘(图中未标出),通过吸盘实现玻璃工件106的吸附;所述旋转气缸1022通过旋转气缸安装块1035固定于下料侧立板1021的一侧,吸盘安装板1023与旋转气缸1022的气缸杆相连接,该吸盘安装板1023在旋转气缸1022的驱动下实现水平状态和竖直状态的切换;通过这种方式,当玻璃工件106位于输送带上,呈水平状态时,可以通过先通过吸盘实现吸附,再通过旋转气缸1022的驱动,使玻璃工件106转换为竖直状态。另外,所述的推料组件设置于下料侧立板1021上,并位于旋转气缸1022的上方,该推料组件用于实现吸盘上工件的下料,本方案中,推料组件是用于将竖直的玻璃工件106推送至已加工玻璃料框107中;具体的,参照图2所示,所述的推料组件包括推动气缸1024、气缸安装板1025以及压块1026;所述的推动气缸1024固定安装在气缸安装板1025的一端,气缸安装板1025的另一端被固定于下料侧立板1021上,所述的压块1026固定安装在推动气缸1024的气缸杆顶端。通过推动气缸1024的作用,实现压块1026在竖直方向上的往复运动,在图2中,当压块1026向下运动后,则将玻璃工件106推出至已加工玻璃料框107中。For the blanking
作为较佳的实施例,参照图7所示,所述的下料驱动组件102还包括工件限位组件,工件限位组件用于在吸盘吸附玻璃工件106后,实现玻璃工件106的夹持;另外还实现下料过程中玻璃工件106的限位,以提高下料时的精确性。该工件限位组件包括限位气缸1027、限位推板1028、左侧支撑板1029、左侧活动导板1030、右侧支撑板1031以及右侧活动导板1032;所述的左侧支撑板1029和右侧支撑板1031相对固定在下料侧立板1021上,为了减轻整体重量,左侧支撑板1029和右侧支撑板1031均呈框架状;所述限位气缸1027固定于下料侧立板1021上并位于左侧支撑板1029和右侧支撑板1031之间,限位推板1028固定于限位气缸1027的气缸杆顶端;本实施例中,限位气缸1027呈横向设置,通过限位气缸固定块1033固定在下料侧立板1021上。As a preferred embodiment, as shown in FIG. 7 , the blanking
进一步的,所述的左侧活动导板1030与限位推板1028固定连接,右侧活动导板1032固定在右侧支撑板1031上,左侧活动导板1030和右侧活动导板1032相对设置,并分别位于吸盘安装板1023的两侧,以用于实现对吸盘上的玻璃工件106的夹持。在本实施例中,所述左侧活动导板1030和右侧活动导板1032相对的侧壁上均设置有向内凹陷的条形槽,该条形槽一方面便于实现对玻璃工件106的夹持,另一方面在压块1026推动玻璃工件106进入已加工玻璃料框107中时,起到了很好的导向作用,使玻璃工件106能够准确的放入至已加工玻璃料框107的预定位置。另外,参照图2所示,左侧活动导板1030和右侧活动导板1032通过腰型孔实现固定,可以对左侧活动导板1030和右侧活动导板1032之间的距离进行调节,通过这种方式以适应不同尺寸的玻璃盖板,提高其适用性,可以实现任意尺寸玻璃工件的下料。Further, the left
更进一步的,在上述的实施例中,所述限位气缸1027的气缸杆穿过于左侧支撑板1029,所述限位推板1028位于左侧支撑板1029的外侧,限位推板1028上固定安装有多个导杆1034,所述左侧支撑板1029上设置有对应数量的导套,导杆1034的一端插入导套内。通过这种结构,限位气缸1027在驱动限位推板1028往复运动过程中,通过导杆1034和导套的配合,能够很好的起到导向作用,避免限位推板1028和左侧活动导板1030的移动出现偏差,提高左侧活动导板1030和右侧活动导板1032对玻璃工件106夹持的精准性。Furthermore, in the above-mentioned embodiment, the cylinder rod of the
结合上述的结构,我们对本发明的一种分片下料机构的工作过程进行说明,首先在下料机构X轴运动模组103和下料机构Z轴运动模组104的配合下,下料驱动组件102运动至待下料的玻璃工件106上方,此时吸盘安装板1023呈水平状,以通过吸盘实现对玻璃工件106的吸附。此后在下料机构X轴运动模组103、下料机构Z轴运动模组104以及下料机构Y轴运动模组105的配合下,将玻璃工件106移动至已加工玻璃料框107的上方,同时在此过程中,旋转气缸1022带动玻璃工件106旋转,使玻璃工件106呈竖直状态,限位气缸1027带动左侧活动导板1030缩回,将玻璃工件106夹持在左侧活动导板1030和右侧活动导板1032的条形槽中。在下料过程中,推动气缸1024的气缸杆伸出,压块1026位于玻璃工件106的正上方,在推动气缸1024的作用力下,玻璃工件106沿着左侧活动导板1030和右侧活动导板1032的条形槽,被转移至已加工玻璃料框107中。为了便于实现玻璃工件106的转移,限位气缸1027可以驱动左右活动导板朝向远离玻璃工件106的方向移动,并通过控制移动量,使得玻璃工件106的两侧始终处于条形槽内,同时避免由于左侧活动导板1030、右侧活动导板1032与玻璃工件106之间的摩擦力过大,而导致无法下料的情况。In combination with the above-mentioned structure, we will describe the working process of a segmented and blanking mechanism of the present invention. First, under the cooperation of the
因此,本发明分片下料机构,能够实现玻璃工件的自动化下料,自动化的将玻璃工件从输送带转移至玻璃料框中,全程无需人工参与,提高了下料效率,降低人工成本。并且,由于工件限位组件的结构设计,能够实现玻璃工件的精准下料,避免玻璃工件在下料过程中出现磕碰,提高了下料的精确性和产品良率。Therefore, the slicing and blanking mechanism of the present invention can realize the automatic blanking of glass workpieces, and automatically transfer the glass workpieces from the conveyor belt to the glass frit frame without manual participation in the whole process, thereby improving blanking efficiency and reducing labor costs. Moreover, due to the structural design of the workpiece limiting component, the glass workpiece can be accurately blanked, and the glass workpiece can be prevented from being bumped during the blanking process, thereby improving the blanking accuracy and product yield.
对于所述的分片上料机构20,参照图8至图11所示,本发明提供了一具体实施例,分片上料机构20包括自动分片结构、玻璃框架13和用于放置玻璃的承载板14,所述承载板14位于玻璃框架13内,所述自动分片结构设置在承载板14和玻璃框架13之间,所述自动分片结构用于对承载板14在玻璃框架13内的大小进行调节。For the above-mentioned slicing and
在进行送料时,玻璃分片模组先将叠放在一起的玻璃进行分离,然后玻璃驱动组件16边可驱动玻璃吸附组件15对分离后的玻璃进行吸取,并驱动玻璃吸附结构将玻璃运送至加工位置。由于玻璃是竖向放置在承载板14上,玻璃框架13在Y轴上的支撑边与玻璃的尺寸相近,可以对玻璃进行稳定支撑,但对于在X轴方向叠放的多层玻璃,玻璃框架13在X轴上的距离决定了玻璃在框架内的稳定性和是否便于取放。而设置的自动分片结构便可调整承载板14在玻璃框架13里面的尺寸,即调整玻璃框架13在X轴方向的尺寸,这样既能保证不对玻璃进行拿取时玻璃放置的稳定,又能保证对玻璃拿取时的轻松。During feeding, the glass slicing module first separates the stacked glass, and then the
参照图10、图11所示,自动分片结构包括推动组件12和滑动组件11,所述玻璃框架13的底部设置有框架底板31,所述推动组件12用于对承载板14及放置在承载板14上的玻璃进行推动,所述滑动组件11用于承载板14和框架底板31之间的滑动。10 and 11 , the automatic slicing structure includes a
所述滑动组件11包括设置在框架底板31上的滑动轴承111和设置在承载板14上的滑道112,所述滑动轴承111在滑道112内滑动设置;所述推动组件12包括弹性推动件和直接推动件,所述直接推动件为设置在玻璃框架13上的吹气杆122,且吹气杆122通过固定块与玻璃框架13上与玻璃竖直面对应的一端固定连。所述滑动轴承111设置有多个,且多组滑动轴承111均匀的设置在框架底板31的两侧,所述滑道112在承载板14的底部与滑动轴承111对应设置;所述弹性推动件为在承载板14底部与框架底板31连接的弹簧121,且在承载板14和框架底板31上均设置有弹簧121活动槽和弹簧121安装扣。The sliding
在需要对玻璃进行取板时,设置在玻璃框架13上的吹气杆122便会对设置在吹气杆122前方的玻璃进行吹气,由于玻璃设置在承载板14上,受到冲击的玻璃向后移动,带动承载板14向后移动。此时承载板14与玻璃框架13上设置有吹气杆122的一侧便会空出一端距离,此时取板的吸附组件便可在空出的空间内对第一个玻璃进行吸附取板。玻璃被取走后,吹气杆122停止吹气,此时玻璃受力消失,而设置在承载板14与框架底板31之间的弹簧121受到的拉力消失,弹簧121回弹,承载板14便带动玻璃回到玻璃与玻璃框架13边缘接触的位置,保证在不进行取板时玻璃的稳定性。When the glass needs to be taken out, the blowing
参照图9,自动分片结构上还设置有玻璃吸附组件15和驱动玻璃吸附组件15的玻璃驱动组件16,所述玻璃吸附组件15用于吸取分片结构中的玻璃,所述玻璃驱动组件16用于对分片结构进行驱动;在进行送料时,玻璃分片模组先将叠放在一起的玻璃进行分离,然后玻璃驱动组件16边可驱动玻璃吸附组件15对分离后的玻璃进行吸取,并驱动玻璃吸附结构将玻璃运送至加工位置。Referring to FIG. 9 , the automatic slicing structure is further provided with a
这种自动化的送料结构不仅节省了人力物力,增加了玻璃送料的效率,在对玻璃进行吸取和放置时,玻璃的位置等参数都可以进行控制,保证了送料时的精确度,便于抛光机对玻璃进行进一步加工。This automatic feeding structure not only saves manpower and material resources, but also increases the efficiency of glass feeding. When the glass is sucked and placed, parameters such as the position of the glass can be controlled, which ensures the accuracy of feeding and is convenient for the polishing machine. Glass for further processing.
本发明的一种高效自动抛光机装置,分片上料机构20进行自动分片及自动上料动作,配备独立的上下料机械手50进行自动上料及下料动作,配备中转流水线40对待加工玻璃及已加工玻璃的自动流转动作,配备分片下料机构10进行独立的下料动作,增加了抛光机的适用范围,能够实现全自动的玻璃工件的自动上料、分片、加工、下料等动作。在对工件进行抛光时,多组同时进行,抛光精度高、效率高、长期使用稳定性好,机身内罩301下方还设有集中排水排污的排水槽,能够实现玻璃工件的全自动化加工以及自动上下料,极大的提高了加工效率的同时节约了人力和成本。In the high-efficiency automatic polishing machine device of the present invention, the slicing and
以上是对本发明的较佳实施进行了具体说明,但本发明创造并不限于所述实施例,熟悉本领域的技术人员在不违背本发明精神的前提下还可做出种种的等同变形或替换,这些等同的变形或替换均包含在本申请权利要求所限定的范围内。The above is a specific description of the preferred implementation of the present invention, but the present invention is not limited to the described embodiments, and those skilled in the art can also make various equivalent deformations or replacements on the premise that does not violate the spirit of the present invention , these equivalent modifications or substitutions are all included within the scope defined by the claims of the present application.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202210475772.5A CN114770263A (en) | 2022-04-29 | 2022-04-29 | Efficient automatic polishing machine device |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202210475772.5A CN114770263A (en) | 2022-04-29 | 2022-04-29 | Efficient automatic polishing machine device |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN114770263A true CN114770263A (en) | 2022-07-22 |
Family
ID=82435230
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202210475772.5A Pending CN114770263A (en) | 2022-04-29 | 2022-04-29 | Efficient automatic polishing machine device |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN114770263A (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN115502866A (en) * | 2022-09-23 | 2022-12-23 | 江西瑞美机械设备有限公司 | Novel high-efficient burnishing machine |
| CN119609921A (en) * | 2024-12-06 | 2025-03-14 | 湖南宇环智能装备有限公司 | Automatic loading and unloading device, polishing machine system and polishing method |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR1026182A (en) * | 1949-08-24 | 1953-04-24 | Saint Gobain | Improvements to processes and apparatus for smoothing flat glass on both sides at the same time |
| CN206170078U (en) * | 2016-08-08 | 2017-05-17 | 苏州托玛斯自动化科技有限公司 | Robotic arm for industrial robot |
| CN111546524A (en) * | 2020-04-10 | 2020-08-18 | 大族激光科技产业集团股份有限公司 | Full-automatic feeding and discharging intelligent CNC machining equipment |
| CN213004545U (en) * | 2020-07-10 | 2021-04-20 | 深圳市盛利达数控设备有限公司 | Scanning device and scanning machine |
| CN217800677U (en) * | 2022-04-29 | 2022-11-15 | 江西瑞美机械设备有限公司 | High-efficient automatic burnishing machine device |
-
2022
- 2022-04-29 CN CN202210475772.5A patent/CN114770263A/en active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR1026182A (en) * | 1949-08-24 | 1953-04-24 | Saint Gobain | Improvements to processes and apparatus for smoothing flat glass on both sides at the same time |
| CN206170078U (en) * | 2016-08-08 | 2017-05-17 | 苏州托玛斯自动化科技有限公司 | Robotic arm for industrial robot |
| CN111546524A (en) * | 2020-04-10 | 2020-08-18 | 大族激光科技产业集团股份有限公司 | Full-automatic feeding and discharging intelligent CNC machining equipment |
| CN213004545U (en) * | 2020-07-10 | 2021-04-20 | 深圳市盛利达数控设备有限公司 | Scanning device and scanning machine |
| CN217800677U (en) * | 2022-04-29 | 2022-11-15 | 江西瑞美机械设备有限公司 | High-efficient automatic burnishing machine device |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN115502866A (en) * | 2022-09-23 | 2022-12-23 | 江西瑞美机械设备有限公司 | Novel high-efficient burnishing machine |
| CN119609921A (en) * | 2024-12-06 | 2025-03-14 | 湖南宇环智能装备有限公司 | Automatic loading and unloading device, polishing machine system and polishing method |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN204222510U (en) | A kind of carving machine of automatic loading/unloading | |
| CN220690820U (en) | A cleaning and detection integrated machine | |
| CN108637664A (en) | The full-automatic package system of the high-accuracy heat dissipation bearing fan of one kind and assembly method | |
| CN217412848U (en) | Light source substrate slitting equipment | |
| CN209973696U (en) | A go up unloader for glass cnc engraving and milling machine | |
| CN105643390A (en) | Double-side in-line intelligent chamfering machine | |
| CN109571234B (en) | Full-automatic grinding production line | |
| CN217991620U (en) | Case plate cutting device | |
| CN111546524A (en) | Full-automatic feeding and discharging intelligent CNC machining equipment | |
| CN115106854A (en) | Numerical control knife sharpener | |
| CN207309619U (en) | A glass chamfering machine | |
| CN218101195U (en) | Automatic ball planting equipment | |
| CN115026694A (en) | Efficient full-automatic polishing machine | |
| CN107553254A (en) | A kind of glass chamfering machine | |
| CN217800677U (en) | High-efficient automatic burnishing machine device | |
| CN210678186U (en) | Burnishing machine retooling tool and have its burnishing machine | |
| CN208304684U (en) | A kind of novel numerical control carving machine | |
| CN107962687A (en) | A kind of machining center and cut machining center equipment | |
| CN219026957U (en) | Edging machine with dust collection structure | |
| CN220913017U (en) | Mobile phone camera support surface defect visual inspection equipment | |
| CN218173865U (en) | Inserted sheet unloading mechanism | |
| CN216399420U (en) | Photovoltaic module positioning mechanism and photovoltaic module framing machine | |
| CN209439948U (en) | A double-platform full-circle grinding and polishing device | |
| CN212170399U (en) | A high-efficiency automatic loading and unloading manipulator equipment | |
| CN206527642U (en) | A kind of Digit Control Machine Tool of new four-tailed bandage automatic loading/unloading |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| TA01 | Transfer of patent application right | ||
| TA01 | Transfer of patent application right |
Effective date of registration: 20240410 Address after: 516200 First Floor, No. 133 Xihu Road, Xihu Village, Qiuchang Street, Huiyang District, Huizhou City, Guangdong Province Applicant after: Huizhou Jingrui Zhixiang Machinery Technology Development Co.,Ltd. Country or region after: China Address before: 337000 lijialang formation, Guanli village, Laoguan Town, Xiangdong District, Pingxiang City, Jiangxi Province Applicant before: Jiangxi Ruimei Machinery Equipment Co.,Ltd. Country or region before: China |