WO2024262174A1 - プレスブレーキ及びプレスブレーキの制御方法 - Google Patents
プレスブレーキ及びプレスブレーキの制御方法 Download PDFInfo
- Publication number
- WO2024262174A1 WO2024262174A1 PCT/JP2024/017126 JP2024017126W WO2024262174A1 WO 2024262174 A1 WO2024262174 A1 WO 2024262174A1 JP 2024017126 W JP2024017126 W JP 2024017126W WO 2024262174 A1 WO2024262174 A1 WO 2024262174A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- angle
- workpiece
- slide
- target
- press brake
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B21—MECHANICAL METAL-WORKING WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D—WORKING OR PROCESSING OF SHEET METAL OR METAL TUBES, RODS OR PROFILES WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D5/00—Bending sheet metal along straight lines, e.g. to form simple curves
- B21D5/02—Bending sheet metal along straight lines, e.g. to form simple curves on press brakes without making use of clamping means
Definitions
- the present invention relates to a press brake and a method for controlling a press brake.
- a press brake is a machine used to bend workpieces. Bending with a press brake causes springback of the metal sheet that is the workpiece. Springback can lead to poor accuracy and processing, so measures to prevent it are essential.
- Patent Document 1 relates to a bending device that bends a workpiece by placing the workpiece between dies consisting of a punch and a die and moving the dies relatively toward and away from each other.
- the bending device includes a die drive means, an angle detection means, a target angle command means, and a fuzzy control means.
- the die drive means moves the dies relatively toward and away from each other.
- the angle detection means detects the bending angle of the workpiece being bent between the two dies.
- the target angle command means outputs a final bending angle that is preset so that the bending angle of the workpiece becomes the product angle after springback as a target angle.
- the fuzzy control means inputs the target angle output by the target angle command means and the bending angle of the workpiece detected by the angle detection means, determines an increment in the command value according to the deviation between the two angles, and controls the die drive means so that the bending angle of the workpiece becomes the target angle.
- Patent Document 1 inputs the target angle and the bending angle of the workpiece, determines a command value increment according to the deviation between the two angles, and controls the die drive means so that the bending angle of the workpiece becomes the target angle.
- the deviation between the target angle and the bending angle of the workpiece becomes smaller as the bending angle of the workpiece approaches the target angle.
- the command value increment determined according to the deviation between the target angle and the bending angle of the workpiece becomes smaller as the deviation between the two angles becomes smaller. Therefore, as the bending angle of the workpiece approaches the target angle, there is a possibility that an error will occur in the command value increment with respect to the increment that should truly be commanded.
- a press brake for use in bending a workpiece is provided.
- the press brake is equipped with a slide that reciprocates to which an upper die is attached.
- the press brake is equipped with a control device that controls the movement of the slide.
- the press brake is equipped with an angle sensor that detects the bending angle of the workpiece.
- the control device converts a target angle when pressurizing the workpiece into a target position to which the slide is moved.
- the control device converts the detected angle detected by the angle sensor into a current position of the slide that corresponds to the detected angle.
- the control device compares the target position with the current position, and performs feedback control that corrects the stroke length to move the slide to a position that corresponds to the difference between the target position and the current position.
- a method for controlling a press brake used for bending a workpiece includes controlling the motion of a slide that reciprocates to which an upper die is attached.
- the method for controlling the press brake includes detecting the bending angle of the workpiece by an angle sensor.
- the method for controlling the press brake converts a target angle when pressurizing the workpiece into a target position to which the slide is moved.
- the method for controlling the press brake converts a detected angle detected by the angle sensor into a current position of the slide corresponding to the detected angle.
- the method for controlling the press brake compares the target position with the current position, and performs feedback control to correct the stroke length so as to move the slide to a position corresponding to the difference between the target position and the current position.
- the press brake of the above embodiment converts the target angle into a target position, converts the detected angle into a current position, and compares the target position with the current position, so even if the difference between the target angle and the detected angle is small, the feedback control has high accuracy.
- the control device may convert the target angle to a target position using a specific function.
- the control device may convert the detected angle to a current position using a specific function. This type of press brake provides consistent accuracy in converting the target angle to a target position and in converting the detected angle to a current position, improving the accuracy of feedback control.
- the control device may perform feedback control at specific time intervals. This type of press brake repeatedly performs feedback control, resulting in greater accuracy.
- the control device may execute feedback control each time the change in the detected angle reaches a specific angle. This type of press brake repeatedly executes feedback control, resulting in higher accuracy.
- the control device may execute control to move the slide toward the initial target position until the upper die contacts the workpiece.
- the control device may start feedback control after the upper die contacts the workpiece. This type of press brake shortens the time it takes for the slide to move until the upper die contacts the workpiece, improving processing efficiency.
- the control device may execute control to move the slide toward the initial target position until the detected angle reaches a predetermined angle.
- the control device may start feedback control after the detected angle reaches the predetermined angle. This type of press brake shortens the time it takes for the slide to move until the detected angle reaches the predetermined angle, thereby improving processing efficiency.
- FIG. 2 is a front view showing an example of the configuration of the press brake 100.
- FIG. 2 is a functional block diagram showing an example of the functional configuration of a control device 160.
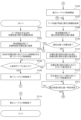
- 4 is a flowchart showing an example of processing of a control device 160.
- FIG. 13 is a functional block diagram showing another example of the functional configuration of the control device 160.
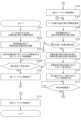
- 10 is a flowchart showing another example of the process of the control device 160.
- 10 is a flowchart showing another example of the process of the control device 160.
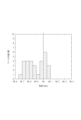
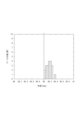
- 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
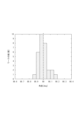
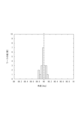
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
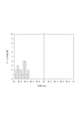
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
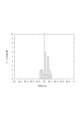
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 that has been bent by feeding back the bending angle of the workpiece W1.
- FIG. 13 is a diagram showing the distribution of bending angles of a workpiece W1 bent by feeding back the position of a slide 130.
- FIG. 1 is a front view showing an example of the configuration of a press brake 100.
- the press brake 100 is a press machine used for bending a workpiece W1.
- the press brake 100 includes a frame 110, a drive unit 120, a slide 130, a back gauge 140, an angle sensor 150, and a control device 160.
- the frame 110 includes a crown 111, an upright 112, and a bed 113.
- the crown 111 is a part that houses the drive unit 120.
- the drive unit 120 is a mechanism that drives the slide 130.
- the drive unit 120 includes, for example, a servo motor that operates the slide 130, a servo valve, a servo amplifier, a feedback detector, and an electric braking device.
- the upright 112 is a part that holds the sliding part of the slide 130.
- the bed 113 is a part that serves as a base that receives press pressure.
- the upper surface of the bed has a structure that allows the attachment of a bolster BP.
- the bolster BP is attached to the upper surface of the bed 113 and is a base plate on which the lower die LT is attached.
- the upper surface of the bolster has a structure that allows the attachment of the lower die LT.
- the lower die LT is a tool that processes the workpiece W1 in combination with the upper die UT.
- the slide 130 is the part to which the upper die UT is attached and which moves back and forth.
- the slide 130 is also called a ram.
- the upper die UT is a tool that is combined with the lower die LT to machine the workpiece W1.
- the backgauge 140 is a tool that determines the position of the workpiece W1 at the rear side of the part where the workpiece W1 is to be bent.
- the backgauge 140 is also called a butt.
- the backgauge 140 is provided so as to be movable in the X direction on the XY plane, for example, by a mechanism not shown.
- the angle sensor 150 is a sensor that detects the bending angle of the workpiece W1.
- the angle sensor 150 is provided at a position in front of the lower die LT and at a position behind the lower die LT when viewed from the front.
- the angle sensor 150 is also provided so as to be movable in the X direction in the XY plane, for example, by a mechanism not shown.
- the control device 160 is a device that controls the movement of the slide 130.
- the control device 160 is electrically connected to the drive unit 120 and the angle sensor 150.
- the control device 160 receives a detection signal from the angle sensor 150 that can identify the bending angle of the workpiece W1.
- the control device 160 transmits a command signal to the drive unit 120 to drive the drive unit 120 to move the slide 130 to the target position.
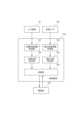
- FIG. 2 is a functional block diagram showing an example of the functional configuration of the control device 160.
- the control device 160 includes a target angle information acquisition unit 161, a target position calculation unit 162, a detection angle information acquisition unit 163, a current position calculation unit 164, and a control unit 165.
- the target angle information acquisition unit 161 is a module that acquires information about the target angle when pressurizing the workpiece W1.
- the target angle information acquisition unit 161 acquires information about the target angle that is input using, for example, the input device 170.
- the input device 170 is a device for providing data, information, instructions, etc. to the main body of a device such as a computer.
- the target position calculation unit 162 is a module that calculates the target position to which the slide 130 is to be moved.
- the target position calculation unit 162 uses the information on the target angle acquired by the target angle information acquisition unit 161 to convert the target angle when pressurizing the workpiece W1 into the target position to which the slide 130 is to be moved.
- the detection angle information acquisition unit 163 is a module that acquires information related to the detection angle detected by the angle sensor 150.
- the detection angle information acquisition unit 163 acquires information related to the detection angle, for example, by sampling the output signal of the angle sensor 150.
- the current position calculation unit 164 is a module that calculates the current position of the slide 130.
- the current position calculation unit 164 converts the detection angle detected by the angle sensor 150 into the current position of the slide 130 corresponding to the detection angle, using information related to the detection angle acquired by the detection angle information acquisition unit 163.
- the control unit 165 is a module that controls the movement of the slide 130.
- the control unit 165 sends a command signal to the servo amplifier of the drive unit 120 to move the slide 130 to the target position.
- the control unit 165 shown in FIG. 2 refers to a feedback signal that indicates the position result when the slide 130 is controlled, which is output from the feedback detector of the drive unit 120.
- the control unit 165 executes a first feedback control that moves the slide 130 toward the initial target position until a specific condition is met. After the specific condition is met, the control unit 165 executes a second feedback control that corrects the stroke length to move the slide 130 to a position corresponding to the difference between the target position and the current position.
- the stroke length is the movement distance of the slide 130 in one process.
- the second feedback control is an example of the "feedback control" in this invention.
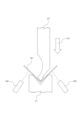
- FIG. 3 is a side view showing the workpiece W1 being pressed by the press brake 100.
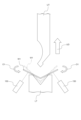
- FIG. 4 is a side view showing the workpiece W1 being unloaded by the press brake 100.
- the workpiece W1 is bent by the slide 130 moving in the downward direction LD and being pressed between the upper die UT and the lower die LT.
- the slide 130 moves in the upward direction UD and the load is removed, the workpiece W1 springs back to the outside O1.
- Springback is the warping that occurs when the workpiece W1 is bent.
- the bending angle of the workpiece W1 after bending is changed by springback when the load is removed. Therefore, the target angle when pressurizing the workpiece W1 is set in anticipation of the change in angle due to springback.
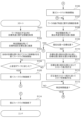
- FIG. 5 is a flowchart showing an example of processing by the control device 160.
- the worker inputs information about the target angle using the input device ID to set the target angle when pressurizing the workpiece W1.
- the target angle information acquisition unit 161 of the control device 160 acquires information about the target angle input using the input device ID (S101).
- the target angle information acquisition unit 161 acquires, as information about the target angle, for example, a parameter indicating the target angle when pressurizing the workpiece W1.
- the target position calculation unit 162 of the control device 160 converts the target angle when pressurizing the workpiece W1 into a target position to which the slide 130 is moved (S102).
- the target position calculation unit 162 identifies the target angle based on the information about the target angle acquired by the target angle information acquisition unit 161.
- the target position calculation unit 162 converts the target angle into a target position, for example, by using a specific function.
- the target position calculation unit 162 uses the function disclosed in Japanese Patent No. 5737657 as the specific function.
- control unit 165 of the control device 160 executes a first feedback control to move the slide 130 toward the initial target position (S103).
- the control unit 165 transmits a command signal to the servo amplifier of the drive unit 120 to move the slide 130 toward the initial target position.
- control unit 165 determines whether the upper die UT attached to the slide 130 has hit the workpiece W1 (S104). In S104, the control unit 165 receives, for example, a feedback signal indicating the position result when the slide 130 is controlled from the feedback detector of the drive unit 120. Then, the control unit 165 determines whether the upper die UT has hit the workpiece W1 by referring to, for example, the predicted position of the slide 130 when the upper die UT hits the workpiece W1 and the feedback signal.
- the control unit 165 repeatedly executes the process of S104 every time a certain amount of time has elapsed, for example, by using an interval timer.
- the interval timer is a mechanism that notifies the user that a certain amount of time has elapsed.
- control unit 165 ends the first feedback control (S105).
- control device 160 starts the second feedback control (S106).
- the detection angle information acquisition unit 163 of the control device 160 acquires information related to the detection angle detected by the angle sensor 150 (S107).
- the detection angle information acquisition unit 163 acquires, as information related to the detection angle, for example, a parameter indicating the detection angle detected by the angle sensor 150.
- the current position calculation unit 164 of the control device 160 converts the detected angle into a current position of the slide 130 corresponding to the detected angle (S108).
- the current position calculation unit 164 converts the detected angle into a current position, for example, by using a specific function.
- the current position calculation unit 164 uses, as the specific function, the same function as that used by the target position calculation unit 162.
- the detection angle information acquisition unit 163 determines whether the current position of the slide 130 has reached the target position (S109).
- the control unit 165 compares the target position with the current position and calculates the difference between the target position and the current position (S110). In S110, the control unit 165 compares the target position calculated by the target position calculation unit 162 with the current position calculated by the current position calculation unit 164 and calculates the difference between the target position and the current position.
- the bending angle of the workpiece W1 is determined by the stroke length of the slide 130. However, even if the stroke length of the slide 130 is the same, the bending angle of the workpiece W1 varies due to differences in the plate thickness, material, and size of the workpiece W1. Also, even if the stroke length of the slide 130 is the same, the bending angle of the workpiece W1 varies due to the deflection of the frame 110, the deflection of the upper die UT, and the deflection of the lower die LT.
- control unit 165 corrects the stroke length to move the slide 130 to a position that corresponds to the difference between the target position and the current position (S111).
- control unit 165 moves the slide 130 using the corrected stroke length as a target (S112).
- control unit 165 sends a command signal to the servo amplifier of the drive unit 120 to move the slide 130 using the corrected stroke length as a target.
- control unit 165 determines whether a specific time has elapsed (S113). In S113, the control unit 165 determines whether a specific time has elapsed after starting control to move the slide 130 with the latest corrected stroke length as a target, for example.
- control unit 165 If the specific time has not elapsed (S113; NO), the control unit 165 repeatedly executes the process of S113 every time a certain time elapses, for example, by using an interval timer.
- control device 160 executes the processes from S107 onwards again.
- the control device 160 repeatedly executes the processes from S107 to S113 until the current position of the slide 130 becomes the target position.
- control device 160 ends the second feedback control (S114) and ends the control shown in the flowchart of FIG. 5.
- the press brake 100 of the above embodiment is used to bend the workpiece W1.
- the press brake 100 is equipped with a slide 130 that reciprocates with an upper die UT attached.
- the press brake 100 is equipped with a control device 160 that controls the movement of the slide 130.
- the press brake 100 is equipped with an angle sensor 150 that detects the bending angle of the workpiece W1.
- the control device 160 converts the target angle when pressurizing the workpiece W1 into a target position to which the slide 130 is moved.
- the control device 160 converts the detected angle detected by the angle sensor 150 into a current position of the slide 130 corresponding to the detected angle.
- the control device 160 compares the target position with the current position and executes a second feedback control that corrects the stroke length to move the slide 130 to a position corresponding to the difference between the target position and the current position.
- This type of press brake 100 converts the target angle into a target position, converts the detected angle into a current position, and compares the target position with the current position, so the accuracy of the second feedback control is high even if the difference between the target angle and the detected angle is small.
- the control device 160 of the above embodiment also converts the target angle into a target position using a specific function.
- the control device 160 of the above embodiment converts the detected angle into a current position using a specific function.
- the press brake 100 of this aspect has the same accuracy in converting the target angle into a target position and the same accuracy in converting the detected angle into a current position, improving the accuracy of the second feedback control.
- control device 160 of the above embodiment executes the second feedback control at specific time intervals.
- the press brake 100 of this aspect repeatedly executes the second feedback control, thereby improving accuracy.
- control device 160 in the above embodiment executes a first feedback control to move the slide 130 toward the initial target position until the upper die UT attached to the slide 130 hits the workpiece W1.
- the control device 160 executes a second feedback control after the upper die UT hits the workpiece W1.
- This aspect of the press brake 100 shortens the movement time of the slide 130 until the upper die UT hits the workpiece W1, thereby improving processing efficiency.
- FIG. 6 is a functional block diagram showing another example of the functional configuration of the control device 160.
- the control device 160 shown in FIG. 6 has a common functional configuration with the control device 160 shown in FIG. 2, except that the control unit 165 refers to the detection angle acquired by the detection angle information acquisition unit 163.
- FIG. 7 is a flowchart showing another example of the processing of the control device 160.
- the processing of the flowchart shown in FIG. 7 is the same as that of the flowchart shown in FIG. 5, except that the detected angle is referenced when the processing from S107 onwards is executed again.
- the control unit 165 determines whether the change in the detected angle has become a specific angle (S213). In S213, the control unit 165 determines whether the change in the detected angle has become a specific angle by referring to the detected angle acquired by the detected angle information acquisition unit 163. The control unit 165 determines whether the change in the detected angle has become a specific angle, for example, after starting control to move the slide 130 with the latest corrected stroke length as a target.
- control unit 165 If the change in the detected angle does not reach a specific angle (S213; NO), the control unit 165 repeatedly executes the process of S113 every time a certain period of time elapses, for example, by using an interval timer.
- control device 160 executes the processes from S107 onwards again.
- the control device 160 repeatedly executes the processes from S107 to S213 until the current position of the slide 130 reaches the target position.
- Fig. 8 is a flowchart showing another example of the process by the control device 160. The process of the flowchart shown in Fig. 8 is common to the flowchart shown in Fig. 5 except that the detected angle is referred to when the first feedback control is ended.
- control unit 165 determines whether the detection angle has become a predetermined angle (S304). In S304, the control unit 165 determines whether the detection angle has become a predetermined angle, for example, by referring to the detection angle acquired by the detection angle information acquisition unit 163.
- control unit 165 If the detected angle is not the specified angle (S304; NO), the control unit 165 repeatedly executes the process of S304 every time a certain period of time elapses, for example, by using an interval timer.
- the control unit 165 ends the first feedback control (S105).
- control device 160 of the above embodiment executes control to move the slide 130 toward the initial target position until the detected angle becomes the predetermined angle.
- the control device 160 starts the second feedback control after the detected angle becomes the predetermined angle.
- the press brake 100 of this aspect shortens the movement time of the slide 130 until the detected angle becomes the predetermined angle, thereby improving the efficiency of processing.
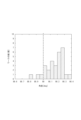
- Figure 9 is a diagram showing the distribution of bending angles of workpiece W1 bent by feeding back the position of slide 130.
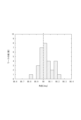
- Figure 10 is a diagram showing the distribution of bending angles of workpiece W1 bent by feeding back the bending angle of workpiece W1.
- the distributions shown in Figures 9 and 10 are both distributions of bending angles when 30 iron workpieces W1 of the same plate thickness and width are bent using a straight sword-shaped upper die UT with a target angle of 90 degrees.
- control for bending by feeding back the position of slide 130 is referred to as position control.
- control for bending by feeding back the bending angle of workpiece W1 is referred to as angle control.
- Fig. 11 is a diagram showing the distribution of bending angles of workpiece W1 bent using position control.
- Fig. 12 is a diagram showing the distribution of bending angles of workpiece W1 bent using angle control.
- the distributions shown in Figs. 11 and 12 are both distributions of bending angles when 30 aluminum workpieces W1 with the same plate thickness and width are bent using a straight-sword shaped upper die UT with a target angle of 90 degrees.
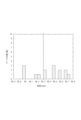
- Figure 13 is a diagram showing the distribution of bending angles of workpiece W1 bent by position control.
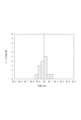
- Figure 14 is a diagram showing the distribution of bending angles of workpiece W1 bent by angle control.
- the distributions shown in Figures 13 and 14 are both distributions of bending angles when 15 iron workpieces W1 with the same plate thickness and width are bent using a gooseneck-shaped upper die UT.
- the target angle in bending by position control is 90.3 degrees.
- the target angle in bending by angle control is 90 degrees.
- Figure 15 is a diagram showing the distribution of bending angles of workpiece W1 bent using position control.
- Figure 16 is a diagram showing the distribution of bending angles of workpiece W1 bent using angle control.
- the distributions shown in Figures 15 and 16 are both distributions of bending angles when 20 workpieces W1 are bent along the roll marks of the workpiece W1 with a target angle of 90 degrees.
- the roll marks are in the rolling direction in the process of turning the workpiece W1 into a plate material.
- Figure 17 is a diagram showing the distribution of bending angles of workpieces W1 bent using position control.
- Figure 18 is a diagram showing the distribution of bending angles of workpieces W1 bent using angle control. The distributions shown in Figures 17 and 18 are both distributions of bending angles when 20 workpieces W1 are bent in a direction intersecting the roll grain of the workpieces W1 with a target angle of 90 degrees.
- the backgage 140 is provided so as to be movable in the X direction on the XY plane by a mechanism not shown.
- the backgage 140 may be immovable.
- the press brake 100 may be provided with a plurality of backgages 140 that are immovable in the X direction on the XY plane.
- the angle sensor 150 is provided at a position in front of the lower die LT and at a position behind the lower die LT when viewed from the front.
- the angle sensor 150 may be provided at either a position in front of the lower die LT or a position behind the lower die LT.
- the angle sensor 150 is arranged to be movable in the X direction in the XY plane by a mechanism not shown.
- the angle sensor 150 may be immovable.
- the press brake 100 may be provided with multiple angle sensors 150 that are immovable in the X direction in the XY plane.
- the control device 160 may send different command signals to the left and right control units 120 to drive the left and right crankshafts individually.
- the crankshaft is an axis that converts the rotational motion into the reciprocating motion of the slide 130.
- the bending process of the long workpiece W1 may cause the bending angle at one end to differ from the bending angle at the other end.
- control device 160 may use the detection result of the angle sensor 150 provided on one end to control the crankshaft on one end, and use the detection result of the angle sensor 150 provided on the other end to control the crankshaft on the other end.
- This type of press brake 100 can prevent the bending angle at one end from misaligning with the bending angle at the other end when bending a long workpiece W1.
- the target angle information acquisition unit 161 acquires parameters indicating the target angle when pressurizing the workpiece W1 as information regarding the target angle.
- the information acquired by the target angle information acquisition unit 161 need only be information regarding the target angle when pressurizing the workpiece W1, and is not limited to parameters indicating the target angle when pressurizing the workpiece W1.
- the target angle information acquisition unit 161 may acquire, for example, parameters that can be used to calculate the target angle when pressurizing the workpiece W1 as information regarding the target angle.
- the detection angle information acquisition unit 163 acquires a parameter indicating the detection angle detected by the angle sensor 150 as information regarding the detection angle.
- the information acquired by the detection angle information acquisition unit 163 may be information regarding the detection angle detected by the angle sensor 150, and is not limited to a parameter indicating the detection angle detected by the angle sensor 150.
- the detection angle information acquisition unit 163 may acquire, for example, a parameter capable of calculating the detection angle detected by the angle sensor 150 as information regarding the detection angle.
- control unit 165 may refer to the detected angle when terminating the first feedback control, similar to the process shown in FIG. 8.
- control device 160 repeatedly executes the second feedback control.
- control device 160 only needs to execute the second feedback control, and may execute the second feedback control only once.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Bending Of Plates, Rods, And Pipes (AREA)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2025527544A JPWO2024262174A1 (cg-RX-API-DMAC7.html) | 2023-06-23 | 2024-05-08 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023-103495 | 2023-06-23 | ||
| JP2023103495 | 2023-06-23 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024262174A1 true WO2024262174A1 (ja) | 2024-12-26 |
Family
ID=93935517
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2024/017126 Ceased WO2024262174A1 (ja) | 2023-06-23 | 2024-05-08 | プレスブレーキ及びプレスブレーキの制御方法 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JPWO2024262174A1 (cg-RX-API-DMAC7.html) |
| WO (1) | WO2024262174A1 (cg-RX-API-DMAC7.html) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7875329B1 (ja) * | 2025-02-19 | 2026-06-17 | 株式会社アマダ | プレスブレーキ、曲げ加工方法及び曲げ加工プログラム |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS62274101A (ja) * | 1986-05-23 | 1987-11-28 | Amada Co Ltd | 油圧機器におけるラム位置決め方法 |
| JPH01210124A (ja) * | 1988-02-18 | 1989-08-23 | Matsushita Electric Works Ltd | 曲げ加工機の曲げ角度制御方法 |
| JPH08300048A (ja) * | 1995-04-27 | 1996-11-19 | Komatsu Ltd | 曲げ加工機 |
| JPH10118717A (ja) * | 1996-10-14 | 1998-05-12 | Komatsu Ltd | 折曲げ機における折曲げ角度補正方法および補正装置 |
| JP2006224144A (ja) * | 2005-02-17 | 2006-08-31 | Amada Co Ltd | 板材折曲げ加工方法及び板材折曲げ加工機 |
-
2024
- 2024-05-08 WO PCT/JP2024/017126 patent/WO2024262174A1/ja not_active Ceased
- 2024-05-08 JP JP2025527544A patent/JPWO2024262174A1/ja active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS62274101A (ja) * | 1986-05-23 | 1987-11-28 | Amada Co Ltd | 油圧機器におけるラム位置決め方法 |
| JPH01210124A (ja) * | 1988-02-18 | 1989-08-23 | Matsushita Electric Works Ltd | 曲げ加工機の曲げ角度制御方法 |
| JPH08300048A (ja) * | 1995-04-27 | 1996-11-19 | Komatsu Ltd | 曲げ加工機 |
| JPH10118717A (ja) * | 1996-10-14 | 1998-05-12 | Komatsu Ltd | 折曲げ機における折曲げ角度補正方法および補正装置 |
| JP2006224144A (ja) * | 2005-02-17 | 2006-08-31 | Amada Co Ltd | 板材折曲げ加工方法及び板材折曲げ加工機 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7875329B1 (ja) * | 2025-02-19 | 2026-06-17 | 株式会社アマダ | プレスブレーキ、曲げ加工方法及び曲げ加工プログラム |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2024262174A1 (cg-RX-API-DMAC7.html) | 2024-12-26 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US4408471A (en) | Press brake having spring-back compensating adaptive control | |
| US11565295B2 (en) | Angle measurement system | |
| CN101678430B (zh) | 薄板的冲压成形装置以及冲压成形方法 | |
| CN111822580B (zh) | 用于操作精细冲裁系统的方法 | |
| US7757526B2 (en) | Method for changing force control gain and die cushion control apparatus | |
| JP2000225414A (ja) | 矯正装置,矯正方法,測定装置及び測定方法 | |
| EP1914019A1 (en) | Press brake and related workpiece bending procedure | |
| JP2004520939A5 (cg-RX-API-DMAC7.html) | ||
| EP1741500B1 (en) | Die cushion mechanism, and device and method for controlling the same | |
| EP1277529B1 (en) | Bending method and bending apparatus | |
| US4075451A (en) | Butt welding apparatus | |
| JP7609645B2 (ja) | プレスシステム及びプレスシステムの制御方法 | |
| CN111151592B (zh) | 一种基于pci-e引脚冲压成型设备的误差检测调整方法 | |
| JP3720099B2 (ja) | 曲げ加工機における板厚検出方法およびその装置並びに曲げ加工方法および曲げ加工機 | |
| EP2205379B1 (en) | Method for determining the optimal insertion force of a fastener press | |
| JP2713773B2 (ja) | 折曲げ加工機の制御方法 | |
| JP6894951B2 (ja) | 曲げ加工方法及び曲げ加工システム | |
| JPH0815624B2 (ja) | 曲げ機械 | |
| JP4878806B2 (ja) | ダイ金型,折曲げ加工方法及び装置 | |
| CN114282610B (zh) | 一种压力机工作能量的检测匹配方法 | |
| JPH0354012B2 (cg-RX-API-DMAC7.html) | ||
| JP2006075880A (ja) | しごき曲げ機における曲げ加工方法及びその装置 | |
| JPH0985350A (ja) | 折曲げ加工機における曲げ加工方法およびこの方法を用いた折曲げ加工機 | |
| JP4002464B2 (ja) | 張力制御を用いた薄板のプレス加工方法及び装置 | |
| JP2869089B2 (ja) | 折曲げ加工機の制御方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 24825583 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2025527544 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 24825583 Country of ref document: EP Kind code of ref document: A1 |