WO2018037779A1 - 認識制御対象車両報知装置 - Google Patents
認識制御対象車両報知装置 Download PDFInfo
- Publication number
- WO2018037779A1 WO2018037779A1 PCT/JP2017/026238 JP2017026238W WO2018037779A1 WO 2018037779 A1 WO2018037779 A1 WO 2018037779A1 JP 2017026238 W JP2017026238 W JP 2017026238W WO 2018037779 A1 WO2018037779 A1 WO 2018037779A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- control target
- target vehicle
- recognition
- automatic driving
- vehicle
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
- G06T7/60—Analysis of geometric attributes
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06T—IMAGE DATA PROCESSING OR GENERATION, IN GENERAL
- G06T7/00—Image analysis
- G06T7/90—Determination of colour characteristics
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
Definitions
- the present invention relates to a recognition control target vehicle notification device that recognizes and notifies a vehicle in the vicinity of the host vehicle.
- the above-described system not only recognizes obstacles and the like from the image signal of the front monitoring camera mounted on the vehicle, and predicts the possibility of vehicle lane departure, rear-end collision, contact with obstacles, etc. based on the image data. These technologies also have the function of following the vehicle ahead and traveling following the lane information.
- Patent Document 2 discloses a technique in which a driver can recognize that a vehicle ahead is recognized by cutting out a region to be controlled from the image signal of the front monitoring camera and displaying it as it is.
- Patent Document 3 describes a technique for improving the same visibility by using an alternative image that matches the direction and orientation of a recognized three-dimensional object.
- Patent Document 4 discloses a technique for discriminating between dynamic pedestrians and static pedestrians and converting only dynamic pedestrians into alert signals.
- Patent Document 1 the invention disclosed in Patent Document 1 described above is limited to cruise control, only notifies the driver of the on / off state and informs the existence of the preceding vehicle in a fixed form. It's hard to say that it's enough.
- Patent Document 2 uses the clipped image and solves the problem of Patent Document 1 in terms of notifying the user of the recognition information of the preceding vehicle, but the original image itself acquired by the camera is used. Since it is cut out, transferred, and displayed, the amount of information to be transferred increases and the transfer time becomes longer. In addition, since the original image is displayed in the small area, the visibility may be deteriorated depending on the acquired scene.
- Patent Document 3 when a plurality of different types of vehicles are present in front of the host vehicle, their postures are almost the same, so that the driver specifies the target vehicle. Have difficulty.
- the present invention has been made in view of the above-described problems, and an object of the present invention is to realize a recognition control target vehicle notification device that allows a driver to accurately recognize a control target vehicle in the vicinity of the host vehicle.
- the present invention is configured as follows.
- the image acquisition unit that acquires an image around the host vehicle
- the type recognition unit that recognizes the type of the recognition control target vehicle from the image acquired by the image acquisition unit
- the type recognition unit A notification information generation unit that generates notification information, and a notification unit that notifies the notification information generated by the notification information generation unit.
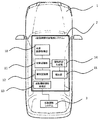
- FIG. 1 is a schematic configuration diagram of a system configuration of a vehicle equipped with a recognition control target vehicle notification device according to the present invention.
- a vehicle (automobile or the like) 1 mainly acquires information about the periphery of the vehicle 1 and automatically recognizes the acquired information, and automatically drives the vehicle 1.
- the driving system 3 is mounted. The automatic driving by the automatic driving system 3 will be described later.
- the recognition control target notification system 2 mainly acquires (recognizes) an automatic driving information acquisition unit 13 that acquires automatic driving information related to whether or not the vehicle 1 is in automatic driving by the automatic driving system 3 from the automatic driving system 3.
- the type recognition unit 12 that recognizes the type (shape, color, etc.) of the recognized target vehicle, and the type of the recognition control target vehicle recognized by the type recognition unit
- An external image acquisition unit 10 that acquires an ambient image), and a notification content generation unit (notification information generation unit) 14 is obtained from the information obtained from the external image acquisition unit 10 and the automatic driving information acquisition unit 13. That on the basis of the automatic operation information to generate a control signal, and is configured to output.
- FIG. 2 is an operation flow of automatic operation in the embodiment of the present invention.
- step S201 the external image recognition acquisition unit 10 determines whether or not the camera state is normalized. If it is determined that it is not normal, the process proceeds to step S209, where the notification unit 15 or the like notifies the abnormality and returns to the start.
- step S201 If it is determined in step S201 that the camera state is normal, the process proceeds to step S202, and the external image recognition unit 10 acquires a surrounding image of the vehicle.
- step S203 each part of the control target recognition system 2 performs initial setting.
- step S204 the object recognition unit 11 detects a white line on the road, and in step S205 detects a three-dimensional object on the road.
- step S206 a control target vehicle is selected from the preceding vehicles, and the process proceeds to step S207.
- Step S207 is a processing step for making it possible for the driver to easily identify the vehicle to be controlled, and includes steps S211 to S215 shown on the right side of FIG.
- step S211 the external image acquisition unit 10 acquires the own vehicle periphery information, and the automatic driving information acquisition unit 13 acquires the automatic driving information regarding whether or not the vehicle 1 is automatically driven by the automatic driving system 3, and Image information and automatic driving information are transmitted to the object recognition unit 11.
- the acquisition of image information by the external image acquisition unit 10 and the acquisition of automatic driving information by the automatic driving information acquisition unit 13 may be performed periodically or at a predetermined timing.
- the acquisition timing of the image information by the external image acquisition unit 10 and the acquisition timing of the automatic driving information by the automatic driving information acquisition unit 13 may be different.
- the object recognition unit 11 of the recognition control target notification system 2 recognizes an object present in the vehicle periphery information based on the transmitted vehicle periphery information, cuts it out as an image, and transmits the image to the type recognition unit 12 ( Step S212).
- the type recognition unit 12 determines the shape of the object based on the clipped image transmitted from the target recognition unit 11 (step S213).
- the type recognizing unit 12 determines the shape of the object, the type recognizing unit 12 further determines the color of the object based on the clipped image transmitted from the target recognizing unit 11 (step S214).
- the shape determination and the color determination timing may be different with the acquisition of the peripheral information by the external image acquisition unit 10.
- the type recognition unit 12 determines the shape and color of the object after cutting out the object, the type recognition unit 12 transmits the object information and the determination result to the notification content generation unit 14 (step S215).
- the notification content generation unit 14 that has received the determination result from the type recognition unit 12 generates notification content according to the transmitted shape and color information (step S216).
- the notification unit 15 that has received the determination result from the notification content generation unit 14 notifies the driver of the vehicle 1 of the cut-out image of the object and the icon including the shape and color of the object as a control signal (step S208).
- Examples of the notification unit 15 include a meter, a liquid crystal screen, a display (LED) lamp, a sound (including a buzzer) generation device, a vibration generation device, and the like. It is conceivable to change the display on the liquid crystal screen, the light from the LED lamp, the sound such as sound, the occurrence of vibration, etc.
- the notification unit 15 notifies the driver of the vehicle 1 with an icon including a cut-out image of the object to be recognized, a shape of the object, and a color by display or voice. Only one of the audio control signals may be generated and notified, or the recognition target may be notified by display and audio. As an example of the sound, the shape and color of the target vehicle will be described.
- the display only the shape or color of the recognition target may be displayed, and only the shape or color of the recognition target may be notified for the sound.
- the notification target object can be divided into two.
- One is an object to be recognized, which is an object for which an image is acquired by the external image acquisition unit 10 and information of the object is retained when the object recognition unit 11 determines the object.
- the other one is a control object that holds information on the recognition object and is a target for controlling the host vehicle 1.
- both the recognition object and the control object may be notified. Further, when both are notified, the notification contents may be changed.
- the information obtained from the automatic driving information acquisition unit 13 may be used as a condition when the notification content generating unit 14 generates the notification content.
- the notification content may be generated and the notification content may be transmitted to the notification unit 15.
- the notification content to be generated is changed between the case where the automatic driving information acquisition unit 13 determines that automatic driving is not being performed by the automatic driving system 3 and the case where it is determined that automatic driving is being performed. You may make it transmit.
- the vehicle 1 When the information obtained from the automatic driving information acquisition unit 13 is used, the vehicle 1 is automatically operated by the automatic driving system 3 from the preparation state before the automatic driving by the automatic driving system 3 (that is, the state of manual driving by the driver). It will be determined whether or not the vehicle has been switched to driving, but switching to automatic driving may be performed manually by a switch operation by the driver of the host vehicle 1 or automatically by the system. .
- the above-mentioned automatic driving system 3 is realized by various automatic driving functions for the purpose of reducing traffic accidents, mitigating traffic congestion, reducing environmental loads, moving support for elderly people, etc., and improving driving comfort.
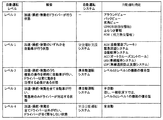
- each of these automatic driving functions is generally classified into a plurality of automatic driving levels (for example, five levels from level 0 to level 4) according to the driver's contribution degree and participation degree (see FIG. 6). ).
- the automatic driving means driving in which the system performs all or part of the driving operation of the vehicle.
- Driving basically means driving in which a driver performs driving operation of a vehicle.
- FIG. 1 In the example shown in FIG.
- the automatic driving level, the automatic driving function, and their classification shown in FIG. 6 are examples, and the present invention is of course not limited to this.
- an automatic driving level 1 AEB automatic emergency brake
- notification is made about the recognition target object and the control target object. It is possible to go.
- the automatic driving level 0 means that the driver performs acceleration, steering and braking, and the automatic driving functions include around view, back view, blind spot view, LDW (lane departure warning), stagger warning, FCW (forward collision warning). )
- the automatic driving level 1 is a state where the vehicle performs any of acceleration (deceleration), steering, and braking, and is a safe driving support system.
- AEB emergency avoidance system
- automatic parking system ACC (auto cruise), LKS (lane keeping system), LDP (lane departure prevention support system).
- the automatic driving level 2 is a semi-automatic driving system in which the vehicle simultaneously performs a plurality of operations of acceleration (deceleration), steering, and braking, and the driver needs to always stop moving.
- the automatic operation function is a combined type of automatic operation level 0 and automatic operation level 1.
- the automatic driving level 3 is a quasi-automatic driving system in which the vehicle performs all of acceleration (deceleration), steering, and braking, and the driver responds only in an emergency.
- the automatic operation function is semi-automatic. However, under some circumstances, it is a composite type of functions of automatic driving level 0 and automatic driving level 1.
- the automatic driving level 4 is a state in which acceleration (deceleration), steering, and braking are all performed by a person other than the driver bar, and the driver is not involved at all, and is a fully automatic driving system.
- the automatic driving function is fully automatic.
- the ACC auto cruise control
- the LDP lassion prevention support system
- the recognition target object and the control target object may be notified.
- the notification content generation unit 14 determines those automatic driving levels or the automatic driving function operated by the automatic driving system 3 based on the automatic driving information transmitted from the automatic driving information acquisition unit 13, and When it is determined that the automatic driving level or the automatic driving function is the predetermined automatic driving level or the automatic driving function (that is, the vehicle 1 has been switched to the predetermined automatic driving level or the automatic driving of the automatic driving function). A control signal for performing the control target notification may be output.
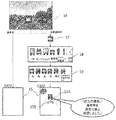
- FIG. 3 to 5 are diagrams specifically illustrating the notification operation
- FIG. 3 is a diagram illustrating an example of the notification operation when a vehicle is recognized in a practical example that operates during automatic driving.
- FIG. 5 is a diagram for explaining an example of a notification operation when a transition is made during automatic driving in a state where a vehicle is recognized in a practical example that operates regardless of whether it is automatic driving.
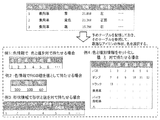
- FIG. 5 is a diagram for explaining an example of table management when data and handling of a notified shape and color are handled.
- the vehicle 1 When the driver or controlled object notification system 2 operates the automatic driving system at a certain point, the vehicle 1 is switched from the manual driving to the automatic driving mode, and the automatic driving information acquisition unit 13 acquires the information switched to the automatic driving. Based on the peripheral information 16 obtained by the external image acquisition unit 10, the target recognition unit 11 recognizes the vehicle existing ahead from the acquired peripheral information. Then, a vehicle image of the recognition control target vehicle among the recognized vehicles is cut out as a cut-out image 17.
- the type recognition unit 12 determines the shape from the shape information 18 and determines the color from the color information 19.
- generation part 14 produces
- the above-described example is an example in which the tracking target is notified to the notification unit 15 during the automatic driving mode, but the vehicle ahead can also be displayed on the notification unit 15 even in a state that is not in the automatic driving mode.
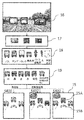
- FIG. 4 is a diagram for explaining an example of a notification operation when transitioning during automatic driving in a state where the vehicle is recognized, and an example in which the preceding vehicle is displayed on the notification unit 15 even in a state that is not in the automatic driving mode. It is explanatory drawing of.
- target vehicle information recognized in the vicinity (information of vehicles recognized other than the recognition control target vehicle) is also displayed before the automatic driving is started (display content S401 of the notification unit 15).
- the automatic driving information acquisition unit 13 acquires information switched to automatic driving, and the surroundings obtained by the external image acquisition unit 10 Based on the information, the object recognition unit 11 recognizes a vehicle that exists in the front and side from the acquired peripheral information 16 and cuts out the vehicle image as an image 17.
- the type recognition unit 12 determines the shape and color based on the cut-out image 17, and the notification content generation unit 14 generates notification content based on these pieces of information, and notifies the notification unit 15 of the notification content.
- the notification content to the notification unit 15 may be a form in which the shape and color are notified to all recognized vehicles (display content S402 (displays information of other recognized vehicles other than the recognition control target vehicle). ) Only the shape of the object that has been recognized may be notified and the color may not be notified, and only the control target vehicle may be notified of the shape and color (display content S403 (the shape and color for the recognition control target vehicle). For vehicles that have been generated and recognized other than the recognition control target vehicle, either shape or color is generated and notified)).
- FIG. 3 shows a case of notifying only object information necessary for control
- FIG. 4 shows an object recognized as an object necessary for control. The case where both of them were reported was shown.
- FIG. 3 shows a case where a notification operation is performed when moving to an automatic driving operation
- FIG. 4 shows a case where a notification operation is performed even before the automatic driving. Either of the cases shown in FIGS. 3 and 4 may be used.
- the table may have a color and a numerical value indicating the color as a pair (Example 1), or may have an individual color such as RGB (Example). 2).
- the shape information may have a pair of a shape and a numerical value (Example 3). Further, the color and the shape information may be paired to have a numerical value (Example 4).
- the target recognition unit 11 recognizes the target and cuts it out as an image.
- the type recognition unit 12 determines the color and shape of the object from the cut out image
- the notification content generation unit 14 generates notification content including the shape and color of the target object, and generates a control signal for controlling the notification unit 15.
- the notification content generation unit 14 acquires automatic driving information regarding whether or not automatic driving is being performed by the automatic driving system 3, and changes the notification content based on the automatic driving information, so that the user can recognize and The state of the object in vehicle control can be recognized accurately.
- this invention is not limited to above-described embodiment, Various deformation
- transformation is included.
- the above-described embodiment has been described in detail for easy understanding of the present invention, and is not necessarily limited to one having all the configurations described.
- a part of the configuration of an embodiment can be replaced with the configuration of another embodiment, and the configuration of another embodiment can be added to the configuration of an embodiment. Further, it is possible to add, delete, and replace other configurations for a part of the configuration of the embodiment.
- control lines and information lines indicate what is considered necessary for the explanation, and not all the control lines and information lines on the product are necessarily shown. Actually, it may be considered that almost all the components are connected to each other.
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Theoretical Computer Science (AREA)
- Geometry (AREA)
- Traffic Control Systems (AREA)
- Image Analysis (AREA)
- Control Of Driving Devices And Active Controlling Of Vehicle (AREA)
Abstract
本発明は、自車両の周辺における制御対象車両を、ドライバーが的確に認識可能な認識制御対象報知装置を実現する。本発明は、外界画像取得部10にて得た画像情報を元に、対象認識部11にて対象物を認識し、画像として切り出す。切り出した画像から種別認識部12が対象物の色と形状を判断する。報知内容生成部14は、対象物の形状と色とからなる報知内容を生成し、報知部15を制御する制御信号を出力して、報知部15に上記対象物の形状と色とからなる報知内容を報知する。これにより、使用者が車両制御における対象物の状態を的確に認知することができる。
Description
本発明は、自車両の周辺における車両を認識し報知する認識制御対象車両報知装置に関する。
近年、交通事故の増大傾向に対して車の安全性の飛躍的向上、即ち最初から危険な状態に陷らないように予防安全を図るため、またドライバーの運転負荷を軽減するため、自動緊急ブレーキシステム、緊急回避システム、オートクルーズコントロールシステム、レーンキープ(車線維持)システム、自動駐車システムなど、車両に搭載されたカメラやレーダから得られる情報を利用して車両の運転操作の一部もしくは全部をシステムが自動で行う様々な自動運転技術(ドライバーの寄与度や関与度に応じて様々な自動運転レベルが存在する)が開発されている。
上述したシステムは、車両に搭載した前方監視カメラの画像信号により障害物等を認識して、その画像データにより車両の車線逸脱、追突、障害物との接触等の可能性を予測するだけでなく、これら技術を利用し前方の車両追従し走行したり、車線情報に追従し走行したり機能も有している。
また、上記した追従走行を有する車両において追従走行時と非追従走行時とで表示形態を異ならせる事項が開示されている。
具体的には、追従するべき先行車両を検出した場合、追従走行の状況を示す画面にて、先行車両表示、自車表示等を表示することにより、前方車両を認識していることをドライバーが認識出来るという効果が得られる技術が特許文献1に記載されている。
また、前方監視カメラの画像信号から制御対象物の領域を切り出して、そのまま表示させることにより、前方車両を認識していることをドライバーが認識出来るという技術が特許文献2に記載されている。
また、認識された立体物の向き、姿勢に合わせた代替画像を用いて、同一視認性を高める技術が特許文献3に記載されている。
また、動的歩行者と静的歩行者とを判別し、動的歩行者のみをアラート信号に変換する技術が特許文献4に記載されている。
しかしながら、上記した特許文献1に開示された発明では、クルーズコントロールに限定し、オンオフ状態をドライバーに知らせ、先行車の存在を決まった形で知らせるだけであり昨今の多様化された車両制御機構に十分対応しているとは言い難い。
具体的には、特許文献1に記載のクルーズコントロールを一例にとった場合、先行車の存在を通知するだけであり、その先行車が具体的に何を対象としたのかは通知していないためオートクルーズコントロールシステムのような自動追従機能にて追従している対象が使用者の認識と合致しているかわからない問題があった。
また、特許文献2に開示された発明では切り出した画像を用い、先行車の認識情報を使用者に通知する面では特許文献1の問題を解決しているが、カメラで取得した原画像そのものを切り出して転送し表示させるため転送する情報量が多くなり、転送時間が長くなる。また、小領域内に原画像を表示させるため、取得したシーンによっては視認性が悪くなる可能性もある。
また、特許文献3に開示された発明では、自車両の前方に複数の車種が異なる車両が存在する場合、それらの姿勢は、ほとんど同一であるから、対象とする車両をドライバーが特定することは困難である。
また、特許文献4に開示された発明では、前方走行中の車両は、全て動的車両であるから、全てがアラート信号に変換さることになり、ドライバーが対象とする車両を特定することは困難である。
本発明は、上述した問題に鑑みてなされたものであり、その目的は、自車両の周辺における制御対象車両を、ドライバーが的確に認識可能な認識制御対象車両報知装置を実現することである。
上記課題を解決するために、本発明は次のように構成される。
認識制御対象車両報知装置において、自車両周囲の画像を取得する画像取得部と、上記画像取得部が取得した画像から認識制御対象車両の種別を認識する種別認識部と、上記種別認識部により認識された認識制御対象車両の種別に基づいて、報知情報を生成する報知情報生成部と、上記報知情報生成部により生成された報知用情報を報知する報知部とを備える。
本発明によれば、自車両の周辺における制御対象車両を、ドライバーが的確に認識可能な認識制御対象車両報知装置を実現することができる。
以下、本発明に係る実施形態について図面を参照して説明する。
図1は、本発明に係る認識制御対象車両報知装置が搭載された車両のシステム構成の概略構成図である。
図1において、車両(自動車等)1には、主に、車両1の周辺の情報を取得し、その取得した情報を報知する認識制御対象報知システム2と、車両1を自動的に運転する自動運転システム3とが搭載されている。なお、自動運転システム3による自動運転については、後述する。
認識制御対象報知システム2は、 主に、車両1が自動運転システム3による自動運転中か否かに関する自動運転情報を自動運転システム3から取得する自動運転情報取得部13と、取得(認識)した画像から認識制御対象車両を認識する対象認識部11と、認識した対象車両の種別(形状、色など)を認識する種別認識部12と、種別認識部で認識した認識制御対象車両の種別に基づいて、報知用内容を生成する報知内容生成部(報知情報生成部)14と、生成された報知用内容を報知(表示、音声出力など)する報知部15と、カメラ等の外界画像(自車両周囲画像)を取得する外界画像取得部10とを有しており、報知内容生成部(報知情報生成部)14は、外界画像取得部10から得られる情報と自動運転情報取得部13から得られる自動運転情報とに基づいて制御信号を生成し、出力するように構成されている。
図2は、本発明の実施例における自動運転の動作フローである。
図2において、ステップS201において、外界画像認識取得部10は、カメラ状態が正常化か否かを判断する。正常でないと判断した場合は、ステップS209に進み、報知部15等により異常通知を行い、スタートに戻る。
ステップS201において、カメラ状態が正常であると判断すると、ステップS202に進み、外界画像認識部10が車両の周辺画像を取得する。次に、ステップS203において、制御対象認識システム2の各部が初期設定を行う。そして、ステップS204において、対象認識部11は、道路の白線を検知し、ステップS205で道路上の立体物を検知する。そして、ステップS206において、先行車両のうちの制御対象車両を選定し、ステップS207に進む。
ステップS207は、制御対象車両をドライバーが容易に特定可能な報知とするための処理ステップであり、図2の右側に示したステップS211からS215からなる。
ステップS211において、外界画像取得部10は自車両周辺情報取得し、自動運転情報取得部13は、車両1が自動運転システム3による自動運転中か否かに関する自動運転情報を取得し、自車両周辺画像情報と自動運転情報とが対象認識部11へ送信される。
なお、外界画像取得部10による画像情報の取得や自動運転情報取得部13による自動運転情報の取得は、定期的に行ってもよいし、予め定めたタイミングで行ってもよい。また、外界画像取得部10による画像情報の取得タイミングと自動運転情報取得部13による自動運転情報の取得タイミングとは異なっていてもよいことは勿論である。
次いで、認識制御対象報知システム2の対象認識部11は送信された車両の周辺情報に基づいて、車両の周辺情報に存在する物体を認識し画像として切り出しし種別認識部12に画像を送信する(ステップS212)。
種別認識部12は、対象認識部11から送信された切り出した画像に基づいて、物体の形状を判定する(ステップS213)。
種別認識部12は、物体の形状を判定した場合、さらに対象認識部11から送信された切り出した画像に基づいて、物体の色を判定する(ステップS214)。
なお、外界画像取得部10による周辺情報の取得に伴い形状の判定と色の判定タイミングは、異なっていてもよいことは勿論である。
種別認識部12は、物体の切り出し後、物体の形状、色を判定した場合、その物体情報や判定結果を報知内容生成部14に送信する(ステップS215)。
種別認識部12から判定結果を受信した報知内容生成部14は、送信された形状、色情報に従い報知内容を生成する(ステップS216)。
報知内容生成部14から判断結果を受信した報知部15は、車両1のドライバーに対して物体の切り出し画像や物体の形状、色を含んだアイコンを制御信号として報知する(ステップS208)。
なお、この報知部15としては、例えば、メーターや液晶画面、表示(LED)ランプ、音声(ブザーを含む)発生装置、振動発生装置などが挙げられ、報知部15による報知方法としては、メーターや液晶画面などの表示変更、LEDランプなどの光、音声などの音、振動などの発生などが考えられる。
上述のような処理を繰り返すことにより、車両1に設けられた報知部15に対して認識対象物を適切に報知することができる。
なお、上記した実施形態では、報知部15が、車両1のドライバーに対して表示や音声にて認識対象の物体の切り出し画像や物体の形状、色を含んだアイコンとして報知するとしたが、表示もしくは音声のどちらか一方のみの制御信号を生成して報知するようにしてもよいし、表示及び音声にて認識対象を報知してもよい。音声の一例としては、対象車両の形状と色を説明するものである。
また、表示については、認識対象の形状のみ又は色のみを表示してもよく、音声についても、認識対象の形状のみ又は色のみを報知してもよい。
また、認識対象物に対して報知を行うことを説明したが、報知対象物は2つに区分けすることができる。一つは、外界画像取得部10にて画像を取得し、対象認識部11にて対象物を判断する際にその対象物の情報を保持しておくだけの対象とする認識対象物である。他の一つは、認識対象物の情報を保持し、かつ自車両1の制御を行う対象とする制御対象物である。
上記認識対象物と制御対象物との両方に対して報知するとしてもよいし、片方だけを報知するようにしてもよい。また、両方報知する際に、それぞれ、その報知内容を変えてもよい。
また、報知内容生成部14にて報知内容を生成する際の条件として自動運転情報取得部13から得た情報を使ってもよい。
例えば、自動運転システム3による自動運転中であると自動運転情報取得部13が判断した場合のみに報知内容生成を行い、報知部15に報知内容を送信するようにしてもよい。また、自動運転システム3による自動運転中でないと自動運転情報取得部13が判断した場合と、自動運転中であると判断した場合とで生成する報知内容を変えて、報知部15に報知内容を送信するようにしてもよい。
なお、自動運転情報取得部13から得た情報を使う場合は、車両1は自動運転システム3による自動運転を行う前の準備状態(すなわち、ドライバーによる手動運転の状態)から自動運転システム3による自動運転に切り替えられた否かを判断することになるが、自動運転への切り替えは、自車両1のドライバーによるスイッチ操作などにより手動で行われてもよいし、システムにより自動で行われてもよい。
ところで、上記した自動運転システム3は、交通事故の低減、交通渋滞の緩和、環境負荷の低減、高齢者等の移動支援、運転の快適性の向上などを目的として、様々な自動運転機能により実現されており、それらの各自動運転機能から得られる情報に基づいて、自動運転中か否かを判断するための自動運転情報を得ることができる。また、それらの各自動運転機能は、一般に、ドライバーの寄与度や関与度などに応じて複数の自動運転レベル(例えば、レベル0~4までの5段階レベル)に分類されている(図6参照)。
ここで、本明細書において、自動運転とは、システムが車両の運転操作の全部もしくは一部を行う運転を意味し、例えば、図6で示す例では自動運転レベル1~4が該当し、手動運転とは、基本的にドライバーが車両の運転操作を行う運転を意味し、例えば図6で示す例では自動運転レベル0が該当する。
なお、図6に示す自動運転レベルや自動運転機能、それらの分類等は一例であり、本発明がこれに限定されないことは勿論である。
上記のように、自動運転システム3による自動運転のなかでも、様々な自動運転レベルの自動運転が存在し、ドライバーが依然として制御対象報知を必要とする自動運転と、ドライバーが制御対象報知を必要としない自動運転とがあると考えられる。
例えば、自動運転システム3による自動運転のうち、自動運転レベル1のAEB(自動緊急ブレーキ)作動時では、車両1周辺の物体との接触を回避するため、認識対象物、制御対象物について報知を行ってもよいと考えられる。
ここで、自動運転レベル0とは、加速、操舵、制動をドライバーが行い、自動運転機能としては、アラウンドビュー、バックビュー、死角ビュー、LDW(車線逸脱警報)、ふらつき警報、FCW(前方衝突警報)がある。
また、自動運転レベル1とは、加速(減速)、操舵、制動のいずれかを自動車が行う状態であり、安全運転支援システムである。自動運転機能としては、AEB、緊急回避システム、自動駐車システム、ACC(オートクルーズ)、LKS(車線維持システム)、LDP(車線逸脱防止支援システム)がある。
また、自動運転レベル2とは、加速(減速)、操舵、制動のうち、複数の操作を同時に自動車が行い、ドライバーは常に動きを中止する必要がある状態であり、準自動運転システムである。自動運転機能としては、自動運転レベル0と自動運転レベル1との複合型である。
また、自動運転レベル3とは、加速(減速)、操舵、制動の全てを自動車が行い、緊急時にのみ、ドライバーが対応する状態であり、準自動運転システムである。自動運転機能としては、半自動である。ただし、一部状況下では、自動運転レベル0と自動運転レベル1との機能の複合型である。
また、自動運転レベル4とは、加速(減速)、操舵、制動を全てドラーバー以外が行い、ドライバーは全く関与しない状態であり、完全自動運転システムである。自動運転機能は、全自動である。
なお、自動運転レベル2~4において、AEB作動時に警報のみが作動している場合でも自動運転レベル1と同様、認識対象物、制御対象物に対して報知したほうがよいと考えられる。
また、自動運転レベル1の他の機能(自動駐車機能等)が作動している場合、ハンドルやアクセル制御がシステム任せ(システム責任)である場合には認識対象物、制御対象物について報知を行ってもよいと考えられるが、ハンドルやアクセル制御がドライバー任せ(ドライバー責任)である場合には認識対象物、制御対象物に対して何もしなくてもよいと考えられる。
また、自動運転レベル2や自動運転レベル3では、例えば、ACC(オートクルーズコントロール)やLDP(車線逸脱防止支援システム)は単体では一時的なハンドルやアクセル制御(例えば車両1を車線内に戻す)だけであるので、ハンドルやアクセル制御の全てをシステムに任せられる可能性のあるLKS(車線維持システム)との組み合わせである場合には、認識対象物、制御対象物について報知を行ってよいと考えられる。
また、自動運転レベル4では、車両1の運転操作の全てをシステムが行う(完全な自動運転)ので、認識対象物、制御対象物について報知を行ってもよいと考えられる。
上記のように、自動運転システム3による自動運転のなかでも、ドライバーが依然として認識対象物、制御対象物について報知を必要とする自動運転と、ドライバーが制御対象報知を必要としない自動運転とがある。このため、報知内容生成部14は、自動運転情報取得部13から送信された自動運転情報に基づいて、それらの自動運転レベルもしくは自動運転システム3により作動している自動運転機能を判断し、その自動運転レベルもしくは自動運転機能が予め定められた自動運転レベルもしくは自動運転機能である(すなわち、車両1が予め定められた自動運転レベルもしくは自動運転機能の自動運転に切り替わった)と判断した場合に、制御対象報知を行うための制御信号を出力するようにしてもよい。
図3~図5は報知動作を具体的に説明した図であり、図3は、自動運転中に動作する実用例において車両を認識した場合の報知動作の一例を説明した図であり、図4は自動運転であるかないかかわらず動作する実用例において車両を認識している状態にて自動運転中に遷移した場合の報知動作の一例を説明した図である。また、図5は、報知する形状や色をデータして取り扱う際のテーブル管理の一例を説明した図である。
図3に示すように、自動運転中でのみ動作する実用例において前方車両を認識した場合、自動運転を開始する前は、報知部15には、周辺の情報として何も表示していない(報知部15の表示内容S301)。
ある地点でドライバーもしくは制御対象報知システム2にて、自動運転システムが作動されて車両1が手動運転から自動運転モードに切り替えられ、自動運転情報取得部13が自動運転に切り替えられた情報を取得すると、外界画像取得部10により得た周辺情報16を元に、対象認識部11は取得していた周辺情報から前方に存在した車両を認識する。
そして、認識した車両のうち、認識制御対象車両の車両映像を切り出し画像17として切り出しする。
そして、認識した車両のうち、認識制御対象車両の車両映像を切り出し画像17として切り出しする。
その後、その切り出し画像17を元に、種別認識部12が形状情報18から形状を判断し、色情報19から色を判断する。そして、報知内容生成部14は、種別認識部12の判断情報を元に、報知内容を生成し(図3には、報知内容は、例として複数の報知内容を示すが、生成する報知内容は、図示した例のうちの一つである)、報知部15に報知内容を通知する。報知部15は表示内容S302に示すように、色彩が施された車種形状画像15Aが表示される。なお、報知部15の表示内容S302には、自車位置を示すマーク15Bが示されているが、これは、必ずしも必要ではない。また、報知部15は、音声にて、例えば、「前方の黄色い乗用車を追従対象としました」と報知する。
上述した例は、自動運転モード中において、報知部15に追従対象を報知する例であるが、自動運転モードではない状態においても前方車両を報知部15に表示することもできる。
図4は、車両を認識している状態にて自動運転中に遷移した場合の報知動作の一例を説明した図であり、自動運転モードではない状態においても前方車両を報知部15に表示する例の説明図である。
図4において、自動運転を開始する前にも周辺の認識した対象車両情報(認識制御対象車両以外に認識した車両の情報)が表示されている(報知部15の表示内容S401)。
ただし、表示内容S401の場合は、前方車両を認識しているが、どの色であるかまでは報知していない。
ある地点でドライバーもしくは制御対象報知システム2にて手動運転から自動運転モードに切り替えられると、自動運転情報取得部13が自動運転に切り替えられた情報を取得し、外界画像取得部10により得た周辺情報を元に、対象認識部11は取得していた周辺情報16から、前方、側方に存在した車両を認識しその車両映像を画像17として切り出しする。
その切り出し画像17を元に、種別認識部12は、形状、色を判断し、報知内容生成部14はこれらの情報を元に報知する内容を生成し、報知部15に報知内容を通知する。
報知部15への報知内容は、認識した車両のすべてに対し、形状と色を通知する形にしてもよいし(表示内容S402(認識制御対象車両以外に認識した他の車両の情報も表示))、認識のみをした対象の形状のみを通知し色を通知せず、制御対象車両のみを形状および色を通知する形にしてもよい(表示内容S403(認識制御対象車両については形状及び色を生成し、認識制御対象車両以外に認識した車両については、形状及び色のうちの何れかを生成して報知))。
なお、図3及び図4に示す例では、報知の方法として、図3は制御に必要な物体情報のみを報知するケースとして示し、図4は、制御に必要な物体と、認識している物体の両方を報知するケースを示した。
また、図3は自動運転動作に移った際に報知動作するケースとし、図4は自動運転前においても報知動作をするケースを示した。図3、図4のどちらのようなケースにしてもよい。
次に、図5を参照して、制御対象車両について色や形状のデータテーブル管理を説明する。
図5に示すように、報知部15における報知内容の生成を行う際に、色や形状の送信用データを取り扱うことになる。その際に、色情報を生成する場合、テーブルに、色とその色を示す数値とを対として持たせてもよいし(例1)、RGBなどの色を個々に持たせてもよい(例2)。
形状情報についても同様に、形状と数値を対として持たせてもよい(例3)。また、色と形状情報とを対として、数値を持たせてもよい(例4)。
以上のように、本発明の実施例によれば、自車両の周辺における認識制御対象車両を、ドライバーが的確に認識可能な認識制御対象車両報知装置を実現することができる。
つまり、本発明の一実施例の認識制御対象報知システム2によれば、外界画像取得部10にて得た画像情報を元に、対象認識部11にて対象物を認識し、画像として切り出し、切り出した画像から種別認識部12が対象物の色と形状を判断し、報知内容生成部14が、対象物の形状と色とからなる報知内容を生成し、報知部15を制御する制御信号を出力して、報知部15に上記対象物の形状と色とからなる報知内容を報知することにより、使用者が車両制御における対象物の状態を的確に認知することができる。
また、報知内容生成部14は、自動運転システム3による自動運転中か否かに関する自動運転情報を取得し、自動運転情報に基づいて、報知する内容を変更することにより、使用者が認識対象および車両制御における対象の状態を的確に認知することができる。
なお、本発明は上記した実施形態に限定されるものではなく、様々な変形が含まれる。
例えば、上記した実施形態は本発明を分かりやすく説明するために詳細に説明したものであり、必ずしも説明した全ての構成を備えるものに限定されるものではない。
例えば、上記した実施形態は本発明を分かりやすく説明するために詳細に説明したものであり、必ずしも説明した全ての構成を備えるものに限定されるものではない。
また、ある実施形態の構成の一部を他の実施形態の構成に置き換えることが可能であり、また、ある実施形態の構成に他の実施形態の構成を加えることも可能である。また、実施形態の構成の一部について、他の構成の追加・削除・置換をすることが可能である。
また、制御線や情報線は説明上必要と考えられるものを示しており、製品上必ずしも全ての制御線や情報線を示しているとは限らない。実際には殆ど全ての構成が相互に接続されていると考えてもよい。
1・・・車両、2・・・制御対象報知システム、3・・・自動運転システム、10・・・外界画像情報取得部、11・・・対象認識部、12・・・種別認識部、13・・・自動運転情報取得部、14・・・報知内容生成部(報知情報生成部)、15・・・報知部、16・・・周辺情報、17・・・切り出し画像、18・・・形状情報、19・・・報知内容
Claims (16)
- 自車両周囲の画像を取得する画像取得部と、
上記画像取得部が取得した画像から認識制御対象車両の種別を認識する種別認識部と、
上記種別認識部により認識された認識制御対象車両の種別に基づいて、報知情報を生成する報知情報生成部と、
上記報知情報生成部により生成された報知用情報を報知する報知部と、
を備えることを特徴とする認識制御対象車両報知装置。 - 請求項1に記載の認識制御対象車両報知装置において、
自動運転情報を取得する自動運転情報取得部を備え、上記報知情報生成部は、上記種別認識部で認識した種別および上記自動運転情報取得部で取得された自動運転情報に基づいて、報知情報を生成することを特徴とする認識制御対象車両報知装置。 - 請求項1に記載の認識制御対象車両報知装置において、
上記報知情報生成部が生成する報知情報は、上記種別認識部により認識された認識制御対象車両の色であることを特徴とする認識制御対象車両報知装置。 - 請求項1に記載の認識制御対象車両報知装置において、
上記報知情報生成部が生成する報知用情報は、上記種別認識部により認識された認識制御対象車両の形状であることを特徴とする認識制御対象車両報知装置。 - 請求項1に記載の認識制御対象車両報知装置において、
上記報知情報生成部が生成する報知情報は、上記種別認識部により認識された認識制御対象車両の種別を説明する音声であることを特徴とする認識制御対象車両報知装置。 - 請求項3、4及び5のうちのいずれか一項に記載の認識制御対象車両報知装置において、
上記報知情報生成部は、上記報知情報を上記報知部で報知させるための制御信号を上記報知部に出力することを特徴とする認識制御対象車両報知装置。 - 請求項1に記載の認識制御対象車両報知装置において、
上記種別認識部は、上記画像取得部が取得した画像から認識制御対象車両の形状及び色を認識し、上記報知情報生成部が生成する報知情報は、上記種別認識部により認識された認識制御対象車両の形状及び色であることを特徴とする認識制御対象車両報知装置。 - 請求項6に記載の認識制御対象車両報知装置において、
上記種別認識部は、上記画像取得部が取得した画像から認識対象車両の形状及び色を認識し、上記報知情報生成部が生成する報知情報は、上記種別認識部により認識された認識制御対象車両の形状、色及び上記認識制御対象車両の種別を説明する音声であることを特徴とする認識制御対象車両報知装置。 - 請求項6に記載の認識制御対象車両報知装置において、
上記報知情報生成部は、上記自動運転情報取得部が自車両の自動運転が行われていることを示す場合にのみ、報知情報を生成することを特徴とする認識制御対象車両報知装置。 - 請求項6に記載の認識制御対象車両報知装置において、
上記報知情報生成部は、上記自動運転情報取得部が自車両の自動運転が行われていないことを示す場合は、上記種別認識部は、認識制御対象車両及び認識制御対象車両以外に認識した車両の形状及び色のうちの何れかを生成して、上記報知部に報知し、上記自動運転情報取得部が自車両の自動運転が行われていることを示す場合には、上記種別認識部は、認識制御対象車両及び認識制御対象車両以外に認識した車両の形状及び色を生成して、上記報知部に報知することを特徴とする認識制御対象車両報知装置。 - 請求項6に記載の認識制御対象車両報知装置において、
上記報知情報生成部は、上記自動運転情報取得部が自車両の自動運転が行われていないことを示す場合は、上記種別認識部は、認識制御対象車両及び認識制御対象車両以外に認識した車両の形状及び色のうちの何れかを生成して、上記報知部に報知し、上記自動運転情報取得部が自車両の自動運転が行われていることを示す場合には、上記種別認識部は、認識制御対象車両については形状及び色を生成し、認識制御対象車両以外に認識した車両については、形状及び色のうちの何れかを生成して、上記報知部に報知することを特徴とする認識制御対象車両報知装置。 - 請求項9、10及び11のうちのいずれか一項に記載の認識制御対象車両報知装置において、
上記自動運転は、複数の自動運転レベルに分類され、上記報知情報生成部は、上記自車両が予め定められた自動運転レベルの自動運転である場合に、上記制御信号を上記報知部に出力することを特徴とする認識制御対象車両報知装置。 - 請求項12に記載の認識制御対象車両報知装置において、
上記予め定められた自動運転レベルの自動運転は、上記自車両を自動的に制動する自動緊急ブレーキ機能を含むことを特徴とする認識制御対象車両報知装置。 - 請求項12に記載の認識制御対象車両報知装置において、
上記予め定められた自動運転レベルの自動運転は、上記自車両の自動的な加減速、操舵、制動のうちのいずれかを含むことを特徴とする認識制御対象車両報知装置。 - 請求項12に記載の認識制御対象車両報知装置において、
上記予め定められた自動運転レベルの自動運転は、上記自車両の自動的な加減速、操舵、制動のすべてを含み、緊急時のみ上記自車両のドライバーが対応することを特徴とする認識制御対象車両報知装置。 - 請求項12に記載の認識制御対象車両報知装置において、
上記予め定められた自動運転レベルの自動運転は、上記自車両の自動的な加減速、操舵、制動のすべてを含むことを特徴とする認識制御対象車両報知装置。
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201780040097.0A CN109416887B (zh) | 2016-08-24 | 2017-07-20 | 识别控制对象车辆报知装置 |
| JP2018535528A JP6619521B2 (ja) | 2016-08-24 | 2017-07-20 | 認識制御対象車両報知装置 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2016163780 | 2016-08-24 | ||
| JP2016-163780 | 2016-08-24 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2018037779A1 true WO2018037779A1 (ja) | 2018-03-01 |
Family
ID=61245684
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2017/026238 Ceased WO2018037779A1 (ja) | 2016-08-24 | 2017-07-20 | 認識制御対象車両報知装置 |
Country Status (3)
| Country | Link |
|---|---|
| JP (1) | JP6619521B2 (ja) |
| CN (1) | CN109416887B (ja) |
| WO (1) | WO2018037779A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112106345A (zh) * | 2018-07-13 | 2020-12-18 | 麦克赛尔株式会社 | 立体摄像装置 |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN110415543A (zh) * | 2019-08-05 | 2019-11-05 | 北京百度网讯科技有限公司 | 车辆信息的交互方法、装置、设备以及存储介质 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2005018548A (ja) * | 2003-06-27 | 2005-01-20 | Alpine Electronics Inc | 周辺車両表示装置 |
| JP2010228471A (ja) * | 2009-03-25 | 2010-10-14 | Denso Corp | 表示装置 |
| JP2015018438A (ja) * | 2013-07-11 | 2015-01-29 | 株式会社デンソー | 走行支援装置 |
| JP2015193329A (ja) * | 2014-03-31 | 2015-11-05 | 日立オートモティブシステムズ株式会社 | 車両の運動制御システム、車両、および、プログラム |
| WO2016109829A1 (en) * | 2014-12-31 | 2016-07-07 | Robert Bosch Gmbh | Autonomous maneuver notification for autonomous vehicles |
Family Cites Families (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0979821A (ja) * | 1995-09-12 | 1997-03-28 | Suzuki Motor Corp | 障害物認識装置 |
| JP2990267B1 (ja) * | 1998-08-27 | 1999-12-13 | 建設省土木研究所長 | 道路情報通信システム |
| JP3895238B2 (ja) * | 2002-08-28 | 2007-03-22 | 株式会社東芝 | 障害物検出装置及びその方法 |
| EP1950098A1 (en) * | 2005-11-17 | 2008-07-30 | Aisin Seiki Kabushiki Kaisha | Parking assisting device and parking assisting method |
| JP4377439B1 (ja) * | 2008-06-12 | 2009-12-02 | 本田技研工業株式会社 | 車両周辺監視装置 |
| US9058746B2 (en) * | 2008-10-02 | 2015-06-16 | Hitachi Automotive Systems, Ltd. | Information processing device associated with vehicle traveling |
| JP5192007B2 (ja) * | 2010-03-12 | 2013-05-08 | 本田技研工業株式会社 | 車両の周辺監視装置 |
| CN102700462B (zh) * | 2012-05-30 | 2015-04-22 | 广东好帮手电子科技股份有限公司 | 全景辅助驾驶系统中的警示装置及警示方法 |
| JP2014061786A (ja) * | 2012-09-21 | 2014-04-10 | Sony Corp | 移動体およびプログラム |
| JP6135618B2 (ja) * | 2014-08-08 | 2017-05-31 | トヨタ自動車株式会社 | 車両制御装置 |
| CN104269073B (zh) * | 2014-09-11 | 2016-05-18 | 同济大学 | 一种基于车车通信的逆向车道超车预警方法 |
| KR101737792B1 (ko) * | 2014-11-10 | 2017-05-19 | 현대모비스 주식회사 | 자율 주행 차량, 자율 주행 관리 장치 및 그 제어 방법 |
-
2017
- 2017-07-20 WO PCT/JP2017/026238 patent/WO2018037779A1/ja not_active Ceased
- 2017-07-20 JP JP2018535528A patent/JP6619521B2/ja active Active
- 2017-07-20 CN CN201780040097.0A patent/CN109416887B/zh active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2005018548A (ja) * | 2003-06-27 | 2005-01-20 | Alpine Electronics Inc | 周辺車両表示装置 |
| JP2010228471A (ja) * | 2009-03-25 | 2010-10-14 | Denso Corp | 表示装置 |
| JP2015018438A (ja) * | 2013-07-11 | 2015-01-29 | 株式会社デンソー | 走行支援装置 |
| JP2015193329A (ja) * | 2014-03-31 | 2015-11-05 | 日立オートモティブシステムズ株式会社 | 車両の運動制御システム、車両、および、プログラム |
| WO2016109829A1 (en) * | 2014-12-31 | 2016-07-07 | Robert Bosch Gmbh | Autonomous maneuver notification for autonomous vehicles |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112106345A (zh) * | 2018-07-13 | 2020-12-18 | 麦克赛尔株式会社 | 立体摄像装置 |
| CN112106345B (zh) * | 2018-07-13 | 2022-02-11 | 麦克赛尔株式会社 | 立体摄像装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP6619521B2 (ja) | 2019-12-11 |
| CN109416887B (zh) | 2021-09-21 |
| CN109416887A (zh) | 2019-03-01 |
| JPWO2018037779A1 (ja) | 2019-06-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7851651B2 (ja) | 車両 | |
| JP5316785B2 (ja) | 運転支援システムおよび運転支援方法 | |
| JP6838124B2 (ja) | 自動運転制御システム | |
| CN104590250B (zh) | 车辆自主辅助驾驶系统与方法 | |
| EP3342665B1 (en) | Pedestrian collision prevention apparatus and method considering pedestrian gaze | |
| US20150166059A1 (en) | Autonomous vehicle driving support system and autonomous driving method performed by the same | |
| US20210188162A1 (en) | Vehicle state alert apparatus and vehicle state alert method | |
| US20130090806A1 (en) | Method for operating a driver assistance system of a motor vehicle and driver assistance system for a motor vehicle | |
| JP4517393B2 (ja) | 運転支援装置 | |
| JP5811543B2 (ja) | 後方車両衝突警報装置 | |
| JP5074441B2 (ja) | メッセージ通信装置、メッセージ通信方法、メッセージ通信システム及びメッセージ通信プログラム | |
| JP2008293099A (ja) | 車両の運転支援装置 | |
| JP2005328181A (ja) | 周囲確認装置 | |
| US20210206315A1 (en) | Ecu and lane departure warning system | |
| JP7814355B2 (ja) | 車両用制御装置、車両制御方法、およびプログラム | |
| US20240375642A1 (en) | Vehicle for Performing Minimal Risk Maneuver and Method of Operating the Same | |
| JP2010195207A (ja) | 運転支援装置 | |
| JP2018090006A (ja) | 運転支援装置 | |
| JP2008097501A (ja) | 運転支援システム及び案内音声出力方法 | |
| JP6619521B2 (ja) | 認識制御対象車両報知装置 | |
| JP2017182587A (ja) | 異常報知装置 | |
| JP2016224553A (ja) | 車両用交通情報表示システム | |
| JP2012048748A (ja) | メッセージ通信装置、メッセージ通信方法、メッセージ通信システム及びメッセージ通信プログラム | |
| JP2008143381A (ja) | 車両用警告システム、車両用警告システムの警告方法 | |
| JP2015185004A (ja) | 運転支援装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 17843266 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2018535528 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 17843266 Country of ref document: EP Kind code of ref document: A1 |