WO2022185672A1 - 鞍乗型車両のブレーキシステム - Google Patents
鞍乗型車両のブレーキシステム Download PDFInfo
- Publication number
- WO2022185672A1 WO2022185672A1 PCT/JP2021/046861 JP2021046861W WO2022185672A1 WO 2022185672 A1 WO2022185672 A1 WO 2022185672A1 JP 2021046861 W JP2021046861 W JP 2021046861W WO 2022185672 A1 WO2022185672 A1 WO 2022185672A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- brake
- fluid pressure
- brake fluid
- angular velocity
- predetermined threshold
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T8/00—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force
- B60T8/17—Using electrical or electronic regulation means to control braking
- B60T8/1701—Braking or traction control means specially adapted for particular types of vehicles
- B60T8/1706—Braking or traction control means specially adapted for particular types of vehicles for single-track vehicles, e.g. motorcycles
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T8/00—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force
- B60T8/26—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force characterised by producing differential braking between front and rear wheels
- B60T8/261—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force characterised by producing differential braking between front and rear wheels specially adapted for use in motorcycles
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T8/00—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force
- B60T8/32—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force responsive to a speed condition, e.g. acceleration or deceleration
- B60T8/321—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force responsive to a speed condition, e.g. acceleration or deceleration deceleration
- B60T8/3225—Systems specially adapted for single-track vehicles, e.g. motorcycles
Definitions
- the present invention relates to a straddle-type vehicle brake system, and more particularly to a straddle-type vehicle brake system that enables automatic control based on information from various sensors.
- Patent Document 1 discloses a braking system in which, when automatically controlling a braking system, first a light braking force is applied to observe changes in the driver's posture, and a target braking force is applied when no significant change occurs. is disclosed.
- the present invention provides a braking system for a straddle-type vehicle having a control device (70) for automatically controlling brake fluid pressures of brakes (BF, BR) in accordance with various information, in which the pitch angular velocity
- a pitch angular velocity detecting means (73) for detecting the pitch angular velocity ( ⁇ ) of the vehicle based on the output of the detector (95) is provided, and the control device (70) controls the front wheel brakes (BF) by the automatic control.
- a first feature is that when the pitch angular velocity ( ⁇ ) becomes equal to or greater than a predetermined threshold while the hydraulic pressure is gradually increased, the degree of increase in the brake hydraulic pressure is reduced or the brake hydraulic pressure at that time is maintained.
- a seat sensor (76) for detecting a seated state of the driver is provided, and the control device (70) sets the predetermined threshold value when the seat sensor (76) does not detect the seated state of the driver.
- the second feature is the point of lowering.
- control device (70) lowers the predetermined threshold value when the road surface on which the vehicle is traveling is determined to be downhill, and increases the predetermined threshold value when the road surface is determined to be uphill. has a third feature.
- the pitch angular velocity detector (95 ), and the control device (70) gradually increases the brake fluid pressure of the front wheel brake (BF) by the automatic control. If the pitch angular velocity ( ⁇ ) becomes equal to or greater than a predetermined threshold value while the pitch angle velocity ( ⁇ ) is being increased to 1, the degree of increase in the brake fluid pressure is reduced or the brake fluid pressure at that time is maintained, so the vehicle changes to a forward-down attitude. It is possible to reduce the speed of As a result, the driver's sense of security can be enhanced.
- a seat sensor (76) for detecting a seated state of the driver is provided, and the control device (70) controls that the seat sensor (76) does not detect the seated state of the driver.
- the predetermined threshold value is lowered. Therefore, by lowering the predetermined threshold value to decrease the degree of increase in the front wheel brake fluid pressure or advance the timing of switching to maintaining the brake fluid pressure at that time, the driver's sense of security can be improved. can be increased.
- the control device (70) lowers the predetermined threshold when the road surface on which the vehicle is traveling is determined to be downhill, and when the road surface is determined to be uphill. Since the predetermined threshold value is increased, if the front wheel brake is applied while traveling downhill, the vehicle tends to be in a forward-downward position. By advancing the timing of switching to maintaining the hydraulic pressure, it is possible to enhance the driver's sense of security. Also, when driving uphill, it is difficult for the vehicle to fall forward even if the front wheel brakes are applied. It is possible to slow down and obtain a high braking force.
- FIG. 1 is a right side view of a motorcycle to which a braking system according to one embodiment of the invention is applied;
- FIG. 1 is a block diagram showing the configuration of a brake system according to this embodiment;
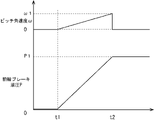
- FIG. 4 is a graph showing changes in pitch angular velocity and front wheel brake hydraulic pressure in automatic control of the brake system;
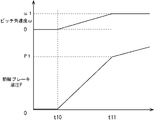
- 4 is a graph showing changes in pitch angular velocity and front wheel brake hydraulic pressure in automatic control of the brake system;
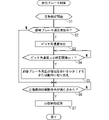
- It is a flow chart which shows a procedure of automatic brake control applied to a brake system concerning this embodiment.
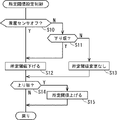
- 4 is a flow chart showing a procedure of predetermined threshold value setting control;
- FIG. 1 is a right side view of a motorcycle 1 to which a braking system according to one embodiment of the invention is applied.
- the motorcycle 1 is a straddle-type vehicle that transmits the driving force of the power unit P to the rear wheels WR via the drive chain 14 .
- a steering stem (not shown) is rotatably supported on a head pipe F1 positioned at the front end of the vehicle body frame F.
- a bottom bridge 23 and a top bridge 24 that support the pair of left and right front forks 10 are fixed above and below the steering stem.
- a steering handle 2 that supports a pair of left and right rearview mirrors 4 is attached to the top of the top bridge 24 .
- a brake lever 50 as a front wheel brake operator is attached to the steering handle 2 on the right side.
- a front wheel brake caliper BF and a front fender 11 are attached to the front fork 10 as a front wheel brake for applying a braking force to a front wheel brake disc 31 that rotates synchronously with the front wheel WF.
- a pair of left and right main frames F2 extending obliquely rearward and downward, and an underframe F5 extending downward and supporting the lower side of the power unit P are attached to the rear portion of the head pipe F1.
- a pivot frame F3 having a pivot 22 that pivotally supports the swing arm 15 is connected to the rear end of the main frame F2, and the rear end of the underframe F5 is connected to the lower end of the pivot frame F3.
- a pair of left and right footrests 39 on which the driver's feet are placed are attached to the pivot frame F3.
- the driving force of the power unit P surrounded and supported by the main frame F2 and the underframe F5 is transmitted to the rear wheels WR via the drive chain 14.
- An underguard 12 is attached to the bottom portion of the power unit P near the front. Combustion gas from the power unit P is sent to the muffler 16 at the rear of the vehicle body through an exhaust pipe 37 passing through the inside of the underguard 12 .
- a rear wheel WR is rotatably supported at the rear end of the swing arm 15 supported by the pivot 22 .
- the swing arm 15 supports a rear wheel brake caliper BR as a rear wheel brake that applies a braking force to a rear wheel brake disc 33 rotating synchronously with the rear wheel WR.
- a brake pedal 50 as a rear wheel brake operator operated by the driver's right foot is pivotally supported on the pivot frame F3 on the right side in the vehicle width direction.
- a front cowl 7 that supports a headlight 9, a windbreak screen 6, and a pair of left and right front flasher lamps 8 is arranged in front of the head pipe F1.
- a fuel tank 3 is arranged behind the front cowl 7 and above the main frame F2.
- a rear frame F4 that supports a front seat 21 on which a driver sits and a rear seat 20 on which a passenger sits is fixed to the rear portion of the pivot frame F3.
- the left and right sides of the rear frame F4 in the vehicle width direction are covered with a rear cowl 19, and a rear fender 38 that supports a tail light device 18 and a pair of left and right rear flasher lamps 17 is attached to the rear end of the rear cowl 19.
- a control device 70 that controls the fuel injection device, the ignition device, the brake system, etc. is arranged on the upper part of the vehicle body frame F.
- the control device 70 includes a front wheel brake actuator (hereinafter also simply referred to as an actuator) 52 that generates brake fluid pressure for the front wheel brakes BF, and a rear wheel brake actuator that generates brake fluid pressure for the rear wheel brakes BR. It is integrated with the brake actuator 62 .
- a front wheel brake fluid pressure sensor 53 for detecting the brake fluid pressure of the front wheel brake BF and a rear wheel brake fluid pressure sensor 63 for detecting the brake fluid pressure of the rear wheel brake BR are arranged near the actuators 52 and 62, respectively. .
- a front wheel brake operation force sensor 51 for detecting an operation force input to the brake lever 50 is arranged near the brake lever 50 , and an operation force input to the brake pedal 60 is located near the brake pedal 60 .
- a rear wheel brake operation force sensor 61 for detecting is provided.
- a seating sensor 21 is arranged inside the front seat 21 to detect the seating state of the driver.
- the seating sensor 21 is turned on when the driver's load is applied, and turned off when the load is not applied. For example, the off state may be determined as being lifted from the seat.
- a road surface sensor 77 is arranged inside the under guard 12 to detect whether or not the road surface is wet.
- a front camera 80 and a front radar 81 used for automatic control of the braking system are installed behind the windbreak screen 6 .
- the actuators 52 and 62 normally, the actuators 52 and 62 generate brake fluid pressure corresponding to the operating force of the brake operators 50 and 60, and the obstacle detected by the front camera 80 and the front radar 81 is detected.
- the optimum brake fluid pressure is automatically generated by the control device 70 even if the brake operators 50 and 60 are not operated.
- the front/rear distribution such as front 7:rear 3 or front 6:rear 4 is automatically set according to the vehicle speed, vehicle attitude, road surface conditions, and the like.
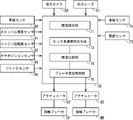
- FIG. 2 is a block diagram showing the configuration of the brake system according to this embodiment.
- the control device 70 includes a threshold value setting portion 71 , a timer 72 , a pitch angular velocity detection means 73 , a threshold value comparison portion 74 and a brake fluid pressure control portion 74 .
- the control device 70 also receives information from a vehicle speed sensor 90, a throttle opening sensor 91, an engine speed sensor 92, a gear position sensor 93, and a gyro sensor 95 as a pitch angular velocity detector. information is entered.
- Information from a seating sensor 76 and a road surface sensor 77 is also input to the control device 70 .
- the gyro sensor 95 can detect roll angular velocity, pitch angular velocity, and yaw angular velocity of the vehicle body. Also, the roll angle, pitch angle, and yaw angle can be calculated based on the angular velocity.
- the brake fluid pressure control unit 72 drives the actuators 52 and 62 based on information from various sensors to exert braking force on the front wheel brake BF and the rear wheel brake BR.
- the pitch angular velocity detection means 73 detects the pitch angular velocity ⁇ based on the output of the gyro sensor 95 .
- the threshold setting unit 71 sets a predetermined threshold based on various sensor information.
- the threshold value comparison unit 74 compares the pitch angular velocity ⁇ with a predetermined threshold value to determine whether to reduce the degree of increase in the brake fluid pressure or to switch to maintenance.
- FIG. 3 is a graph showing changes in the pitch angular velocity ⁇ and the front wheel brake hydraulic pressure P during automatic control of the brake system.
- This graph shows a state in which the automatic control is started at time t1 to start increasing the front wheel brake hydraulic pressure P, and the pitch angular velocity ⁇ reaches the predetermined threshold value ⁇ 1 at time t2.
- This embodiment is characterized in that when the pitch angular velocity ⁇ reaches a predetermined threshold value ⁇ 1 as the front wheel brake fluid pressure P increases, the front wheel brake fluid pressure P is maintained at the value P1 at that time.
- the front wheel brake hydraulic pressure P may be increased linearly as shown in the drawing, or may be increased in a curved line or stepwise manner.
- FIG. 4 is a graph showing changes in the pitch angular velocity ⁇ and the front wheel brake fluid pressure P during automatic control of the brake system.
- This graph shows a state in which the automatic control is started at time t10 to start increasing the front wheel brake hydraulic pressure P, and the pitch angular velocity ⁇ reaches the predetermined threshold value ⁇ 1 at time t11.
- This embodiment is characterized in that when the pitch angular velocity ⁇ reaches a predetermined threshold value ⁇ 1 as the front wheel brake fluid pressure P increases, the degree of increase in the front wheel brake fluid pressure P is decreased (the slope of the graph is decreased). .
- Various modifications are possible for the manner in which the degree of increase is reduced.
- FIG. 5 is a flowchart showing the procedure of automatic brake control applied to the brake system according to this embodiment.
- step S1 automatic control of the brake system is started. It should be noted that the automatic control can be set to be started after it is detected whether or not the driver is gripping the steering wheel 2 .
- step S2 it is determined whether or not the front wheel brake fluid pressure P is increasing, and if the determination is affirmative, the process proceeds to step S3.
- step S3 the pitch angular velocity detection means 73 detects the pitch angular velocity ⁇ .
- step S4 it is determined whether or not the pitch angular velocity ⁇ is equal to or greater than a predetermined threshold value ⁇ 1. If an affirmative determination is made in step S4, the process proceeds to step S5, where the front wheel brake hydraulic pressure P is switched from increasing to decreasing or maintaining the hydraulic pressure gradient.
- step S6 it is determined whether or not the condition for canceling the automatic control of the brake system is satisfied, and if the determination is affirmative, the process proceeds to step S7.
- the conditions for canceling the automatic control are set such that the vehicle speed is below a predetermined value, the operation force of the brake operator is above a predetermined value, the throttle operation amount and operation speed are above a predetermined value, and the vehicle body roll angle is above a predetermined value.
- step S7 automatic control is canceled and switched to manual control, ending a series of controls. If a negative determination is made in step S2, steps S3 to S5 are skipped and the process proceeds to step S6.
- FIG. 6 is a flow chart showing the procedure of predetermined threshold value setting control.
- step S10 it is determined whether or not the seating sensor 76 is off, and if an affirmative determination is made, the process proceeds to step S12 to lower the predetermined threshold value. That is, when it is determined that the seat sensor 76 is off and the driver is standing while riding, the predetermined threshold value is lowered to decrease the degree of increase in the front wheel brake fluid pressure P, or to decrease the brake fluid pressure at that time. By advancing the timing of switching to maintenance, it is possible to enhance the driver's sense of security.
- step S10 determines whether or not the road surface is downhill. If an affirmative determination is made in step S11, the process proceeds to step S12 and the predetermined threshold value ⁇ 1 is decreased. That is, when the front wheel brake BF is operated while driving on a downhill, the front wheel tends to fall forward. By advancing the timing of switching to maintenance of .
- step S11 If a negative determination is made in step S11, the predetermined threshold value ⁇ 1 does not need to be lowered, and the process proceeds to step S13, maintaining the predetermined threshold value ⁇ 1, and proceeds to step S14. It should be noted that the extent to which the predetermined threshold value ⁇ 1 is lowered can be varied, for example, between several percent and several tens of percent depending on the slope of the downhill, the vehicle speed, and the like.
- step S14 it is determined whether or not the road surface is an uphill. That is, when driving on an uphill, it is difficult for the vehicle to fall forward even if the front wheel brake BF is operated. can be slowed down to obtain a high braking force. On the other hand, if a negative determination is made in step S14, the series of control ends. It should be noted that the extent to which the predetermined threshold value ⁇ 1 is raised can be changed between several percent and several tens of percent depending on the slope of the uphill.
- the configuration of the motorcycle, the configuration of the brake system, the aspects of the front wheel brake operator and the rear wheel brake operator, the setting of the predetermined threshold value, the aspect of the pitch angular velocity detector, etc. are not limited to the above-described embodiments, and various modifications are possible. It is possible. For example, when the pitch angular velocity becomes equal to or greater than a predetermined threshold, the brake fluid pressure may be switched from increasing to decreasing. Further, when the pitch angular velocity is reduced by changing the brake fluid pressure from increasing to maintaining, the brake fluid pressure can be increased again.
- the device can be configured to lower the threshold.
- the brake system according to the present invention can be applied not only to motorcycles, but also to saddle type three-wheeled vehicles and four-wheeled vehicles.
Landscapes
- Engineering & Computer Science (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Regulating Braking Force (AREA)
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US18/277,704 US20240123956A1 (en) | 2021-03-04 | 2021-12-17 | Brake system for saddled vehicle |
| DE112021006645.5T DE112021006645T5 (de) | 2021-03-04 | 2021-12-17 | Bremssystem für ein sattelsitzfahrzeug |
| JP2023503394A JP7554903B2 (ja) | 2021-03-04 | 2021-12-17 | 鞍乗型車両のブレーキシステム |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-034321 | 2021-03-04 | ||
| JP2021034321 | 2021-03-04 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022185672A1 true WO2022185672A1 (ja) | 2022-09-09 |
Family
ID=83155293
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2021/046861 Ceased WO2022185672A1 (ja) | 2021-03-04 | 2021-12-17 | 鞍乗型車両のブレーキシステム |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US20240123956A1 (cg-RX-API-DMAC10.html) |
| JP (1) | JP7554903B2 (cg-RX-API-DMAC10.html) |
| DE (1) | DE112021006645T5 (cg-RX-API-DMAC10.html) |
| WO (1) | WO2022185672A1 (cg-RX-API-DMAC10.html) |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2022185671A1 (ja) * | 2021-03-04 | 2022-09-09 | 本田技研工業株式会社 | 鞍乗型車両のブレーキシステム |
| WO2022185698A1 (ja) * | 2021-03-04 | 2022-09-09 | 本田技研工業株式会社 | 鞍乗型車両のブレーキシステム |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2016037254A (ja) * | 2014-08-08 | 2016-03-22 | 本田技研工業株式会社 | 鞍乗型車両の制動力制御装置 |
| WO2019131504A1 (ja) * | 2017-12-28 | 2019-07-04 | 本田技研工業株式会社 | 鞍乗り型車両 |
| WO2020202261A1 (ja) * | 2019-03-29 | 2020-10-08 | 本田技研工業株式会社 | 鞍乗り型車両の運転支援装置 |
Family Cites Families (19)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5324102A (en) * | 1991-10-18 | 1994-06-28 | Fag Kugelfischer Georg Schafer Kgaa | Method and apparatus for regulating the braking force of motorcycles |
| DE19844540A1 (de) * | 1998-09-29 | 2000-03-30 | Bosch Gmbh Robert | Anordnungen und Verfahren zur Vermeidung von Überschlägen bei Bremsvorgängen oder Beschleunigungsvorgängen für Kraftfahrzeuge |
| JP2004509006A (ja) * | 2000-09-13 | 2004-03-25 | エフティーイー・オートモーティブ・ゲーエムベーハー | シングルトラックの車両のホイールでのブレーキ力を制御する方法及び該方法を実行するためのブレーキ装置 |
| US20090152940A1 (en) * | 2003-08-22 | 2009-06-18 | Bombardier Recreational Products Inc. | Three-wheel vehicle electronic stability system |
| DE102005005390A1 (de) * | 2004-10-13 | 2006-05-24 | Continental Teves Ag & Co. Ohg | Kraftradbremsanlage |
| JP4976724B2 (ja) * | 2006-03-31 | 2012-07-18 | 日信工業株式会社 | 車両用ブレーキ液圧制御装置 |
| WO2007118760A1 (de) * | 2006-04-11 | 2007-10-25 | Continental Teves Ag & Co. Ohg | Verfahren zur regelung des druckes in einem elektronisch gesteuerten bremssystem und elektronisches bremssystem |
| US8260535B2 (en) * | 2007-09-28 | 2012-09-04 | Bombardier Recreational Products Inc. | Load sensor for a vehicle electronic stability system |
| JP4602428B2 (ja) * | 2008-02-14 | 2010-12-22 | 日信工業株式会社 | バーハンドル車両用ブレーキ液圧制御装置 |
| JP5143775B2 (ja) * | 2009-03-30 | 2013-02-13 | 本田技研工業株式会社 | 自動二輪車のブレーキ装置 |
| JP5820591B2 (ja) * | 2011-02-14 | 2015-11-24 | 本田技研工業株式会社 | 自動二輪車のブレーキ装置 |
| JP2015051672A (ja) * | 2013-09-05 | 2015-03-19 | 日立オートモティブシステムズ株式会社 | ブレーキシステム及びブレーキ装置及びブレーキ制御方法 |
| DE102014210382A1 (de) * | 2014-06-03 | 2015-12-03 | Robert Bosch Gmbh | Verfahren zur Verteilung einer Bremskraft und Bremseinrichtung |
| US11358574B2 (en) * | 2016-03-31 | 2022-06-14 | Honda Motor Co., Ltd. | Brake control device for motorcycle |
| JP6621774B2 (ja) * | 2017-03-14 | 2019-12-18 | 日信工業株式会社 | バーハンドル車両用ブレーキ液圧制御装置 |
| JP6606115B2 (ja) * | 2017-03-14 | 2019-11-13 | 日信工業株式会社 | バーハンドル車両用ブレーキ液圧制御装置 |
| JP2018176831A (ja) * | 2017-04-05 | 2018-11-15 | ローベルト ボッシュ ゲゼルシャフト ミット ベシュレンクテル ハフツング | 制御装置、制御方法及びブレーキシステム |
| JP6991434B2 (ja) * | 2017-05-24 | 2022-01-12 | カワサキモータース株式会社 | 鞍乗型車両の制御装置 |
| JP7253422B2 (ja) | 2019-03-28 | 2023-04-06 | 本田技研工業株式会社 | 鞍乗り型車両の自動制御装置 |
-
2021
- 2021-12-17 DE DE112021006645.5T patent/DE112021006645T5/de active Pending
- 2021-12-17 WO PCT/JP2021/046861 patent/WO2022185672A1/ja not_active Ceased
- 2021-12-17 JP JP2023503394A patent/JP7554903B2/ja active Active
- 2021-12-17 US US18/277,704 patent/US20240123956A1/en active Pending
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2016037254A (ja) * | 2014-08-08 | 2016-03-22 | 本田技研工業株式会社 | 鞍乗型車両の制動力制御装置 |
| WO2019131504A1 (ja) * | 2017-12-28 | 2019-07-04 | 本田技研工業株式会社 | 鞍乗り型車両 |
| WO2020202261A1 (ja) * | 2019-03-29 | 2020-10-08 | 本田技研工業株式会社 | 鞍乗り型車両の運転支援装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| US20240123956A1 (en) | 2024-04-18 |
| DE112021006645T5 (de) | 2023-10-19 |
| JPWO2022185672A1 (cg-RX-API-DMAC10.html) | 2022-09-09 |
| JP7554903B2 (ja) | 2024-09-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7428852B2 (ja) | 鞍乗型車両のブレーキシステム | |
| JP7014760B2 (ja) | 鞍乗り型車両の操舵アシスト装置 | |
| WO2019130743A1 (ja) | 鞍乗り型車両のブレーキ装置 | |
| CN111527295B (zh) | 鞍乘型车辆 | |
| JPWO2022185698A5 (cg-RX-API-DMAC10.html) | ||
| JP5402466B2 (ja) | 車両の状態検出装置、及び車両の状態安定化制御装置 | |
| JP6833667B2 (ja) | 車両 | |
| JP7554903B2 (ja) | 鞍乗型車両のブレーキシステム | |
| JP7198696B2 (ja) | 自動二輪車 | |
| JP7168684B2 (ja) | 制御装置及び制御方法 | |
| JP7430475B2 (ja) | 鞍乗型車両のブレーキシステム | |
| TWI604978B (zh) | 驅動轉矩控制裝置、驅動源單元及車輛 | |
| US20220306101A1 (en) | Automatic control device for motorcycle | |
| US11858485B2 (en) | Straddle type vehicle, vehicle control apparatus, vehicle control method, and non-transitory computer-readable storage medium | |
| JP5634295B2 (ja) | 自動二輪車の姿勢制御装置及び姿勢制御方法 | |
| JP5945571B2 (ja) | トラクション制御システムおよび鞍乗り型車両 | |
| US12466372B2 (en) | Saddled vehicle | |
| WO2024203085A1 (ja) | 車両制御システム、及び鞍乗型車両 | |
| US20240400014A1 (en) | Control device for motorcycle | |
| US12448070B2 (en) | Tilting vehicle with at least three wheels, a safety device, and a method | |
| WO2022195997A1 (ja) | 鞍乗型車両 | |
| JP7499401B2 (ja) | 自動二輪車の自動吹鳴装置 | |
| EP4365041A1 (en) | Straddled vehicle | |
| WO2026069640A1 (ja) | 車両制御装置 | |
| WO2024153997A1 (ja) | 制御装置及び制御方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21929229 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2023503394 Country of ref document: JP Kind code of ref document: A |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 18277704 Country of ref document: US |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 112021006645 Country of ref document: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 21929229 Country of ref document: EP Kind code of ref document: A1 |