WO2020228310A1 - 一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法 - Google Patents
一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法 Download PDFInfo
- Publication number
- WO2020228310A1 WO2020228310A1 PCT/CN2019/124148 CN2019124148W WO2020228310A1 WO 2020228310 A1 WO2020228310 A1 WO 2020228310A1 CN 2019124148 W CN2019124148 W CN 2019124148W WO 2020228310 A1 WO2020228310 A1 WO 2020228310A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- uncertainty
- interval
- vector
- individuals
- probability
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F30/00—Computer-aided design [CAD]
- G06F30/10—Geometric CAD
- G06F30/17—Mechanical parametric or variational design
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N3/00—Computing arrangements based on biological models
- G06N3/12—Computing arrangements based on biological models using genetic models
- G06N3/126—Evolutionary algorithms, e.g. genetic algorithms or genetic programming
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06F—ELECTRIC DIGITAL DATA PROCESSING
- G06F30/00—Computer-aided design [CAD]
- G06F30/20—Design optimisation, verification or simulation
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N5/00—Computing arrangements using knowledge-based models
- G06N5/01—Dynamic search techniques; Heuristics; Dynamic trees; Branch-and-bound
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06N—COMPUTING ARRANGEMENTS BASED ON SPECIFIC COMPUTATIONAL MODELS
- G06N7/00—Computing arrangements based on specific mathematical models
- G06N7/01—Probabilistic graphical models, e.g. probabilistic networks
Definitions
- the invention belongs to the field of equipment structure optimization design, and relates to a robust optimization design method of a mechanical arm based on the mixed uncertainty of interval and bounded probability.
- the size of the manipulator arm and the position of the hinge point directly affect the working torque, work efficiency and other performance indicators of the manipulator. Therefore, after determining the length of the main structural members of the manipulator, the length and the length of the remaining guide members in the mechanism must be determined. The position of each hinge point is optimized to ensure its working performance.
- the existing methods solve the robust optimization design model that uses normal distribution parameters to describe the probability uncertainty, they usually perform the conversion of the constraint performance function and the robustness evaluation based on the 6 ⁇ robustness design criterion, and introduce a weight factor To transform the uncertain target performance function, the errors generated in the process of model transformation will inevitably lead to the unreliable results of robust optimization design, and the selection of weight factors is also subjective.
- the existing methods are based on Monte Carlo simulation to analyze the robustness of the uncertain target performance function, the distribution characteristics of the probability uncertainty of the target performance function are often not fully reflected due to the loose distribution of sampling points. Specifically, the existing sampling method has insufficient sampling point density near the uncertainty parameter mean point with high contribution degree, and the sampling point density near the sampling boundary with low contribution degree is too high, which makes it difficult to ensure the robustness of the target performance function. The accuracy of the analysis results.
- the present invention provides a robust optimization design method of a mechanical arm based on the mixed uncertainty of interval and bounded probability.
- the two types of uncertainties of hydraulic cylinder driving oil pressure, manufacturing tolerances and material properties of the manipulator, and probability the latter is described by the generalized beta distribution (GBeta distribution), and the inclusion interval and bounded probability are mixed.
- Deterministic robust optimization design model of the robotic arm based on genetic algorithm to directly solve the robust optimization model: First, perform robustness analysis of the constraint performance function for all individuals using the boundedness of mixed uncertainty, and analyze the current population based on the analysis results For fully feasible individuals, the Monte Carlo method based on multi-layer encrypted Latin hypercube sampling is further used to calculate the mean and standard deviation of the objective function; then, the total feasible robustness index and negative ideal solution based on the constraint performance function The current population individuals are sorted and optimized directly at close distance, thereby efficiently solving the robust optimization design problem of the robotic arm under the coexistence of probability and interval mixed uncertainty.
- a robust optimization design method of a mechanical arm based on the mixed uncertainty of interval and bounded probability includes the following steps:
- I a probability density function of the parameters X i; ⁇ ( ⁇ ) is the gamma function;
- the generalized beta distribution and its probability density function are the first descriptive models proposed to avoid the unreasonableness of using the unbounded probability uncertainty parameters of the normal distribution to describe the probability uncertainty.
- the basic principle is to keep the beta distribution in The bounded distribution on the standard interval [0,1] and the relative controllability of its distribution parameters are used to establish a mapping relationship between the standard interval and the actual probability uncertainty parameter distribution interval of the project through linear transformation to promote the bounded distribution.
- the proposed generalized beta distribution is used to describe the probability uncertainty parameters in engineering problems. In addition to fully retaining the probability and statistical information of the original uncertainty parameters (ie its mean and variance), it also avoids the unreasonable uncertainty parameters. The possibility of numerical value also avoids the model error caused by transforming the constraint function when solving the existing optimization model based on normal distribution.
- d (d 1 ,d 2 ,...,d l ) is the l-dimensional design vector
- U (U 1 , U 2 ,..., U n ) is an n-dimensional interval uncertainty vector
- B i is an interval constant given according to design requirements, with Are the left and right bounds of B i , when When, the interval constant B i degenerates into a real number
- p is the number of constraint performance functions; They are the left and right bounds of the performance change interval of the constraint function under the combined influence of the interval and bounded probability mixed uncertainty of the i-th constraint performance function g i (d, X, U).
- the calculation methods are as follows:
- f L (d, ⁇ X ), f R (d, ⁇ X ), f C (d, ⁇ X ), f W (d, ⁇ X ) do not contain any uncertainty parameters, Its values are all real numbers;
- the target performance function corresponding to each sampling point does not contain any uncertainty, and its value is a real number; then the Monte Carlo method is used Calculate the mean value of the midpoint of the change interval of the objective performance function f(d, X, U) under the joint influence of the bounded probability uncertainty vector X and the interval uncertainty vector U Standard deviation of midpoint Mean radius Standard deviation from radius details as follows:
- the original multi-layer encrypted Latin hypercube sampling method proposed by this patent retains the advantages of the traditional single-layer Latin hypercube sampling. At the same time, it focuses on the sample distribution near the mean point that contributes to the statistical parameters of the objective function.
- the sampling space is further divided into the sampling space of the mean neighborhood layer near the mean point according to the probability cumulative function Sampling space with transition layer. The sampling can better reflect the actual performance of the target performance function, and reduce the samples with low contribution at the left and right bounds of the bounded probability uncertainty parameter, thereby further improving the accuracy of the robustness evaluation of the target performance function.
- step 3.6 Determine whether the maximum number of iterations or convergence conditions are met. If so, output the design vector corresponding to the individual with the greatest fitness as the optimal solution; otherwise, perform crossover and mutation operations, and increase the number of iterations by 1 to generate a new generation of population individuals , Return to step 3.2).
- N is the total sampling scale
- N is the total sampling scale
- step 3.2 is specifically as follows:
- the setting factors are calculated according to Eq.16:
- sign( ⁇ ) is a sign function
- S i is the feasible robustness index of the i-th constraint performance function g i (d, X, U), and p is the number of constraint performance functions.
- step 3.5 is specifically as follows:
- n 1 is the total number of fully feasible individuals
- the bounded probability variable that obeys the generalized beta distribution is used to describe the probability uncertainty, so that the value of the constraint performance function of the manipulator affected by the mixed uncertainty of the probability interval also fluctuates with bounded probability, so it can be directly based on the constraint performance
- the upper and lower bounds of the fluctuation of the function under the influence of the mixed uncertainty of the probability interval evaluate its robustness, avoiding the conversion process of the constraint performance function based on the 6 ⁇ robustness design criterion when the normal distribution variable is used to describe the probability uncertainty parameter.
- the simplified error of obtains a more accurate evaluation result of the robustness of the constraint performance function.
- Figure 1 is a flowchart of a robust optimization design method for a manipulator based on mixed uncertainty of interval and bounded probability
- Figure 2 is a three-dimensional model of the robotic arm
- Figure 3 is a schematic diagram of the mechanical arm mechanism.
- Fig. 1 is a flow chart of the robust optimization design method of the manipulator based on the mixed uncertainty of interval and bounded probability.
- FIG. 3 robot arm as the research object, consider the error of manufacture and installation, the length of the arm shown in FIG. 3 is a section l FQ described variables; the same link and the manufacturing accuracy, require lower rocker material
- the density ⁇ linkage sample data is relatively lacking, so it is described as an interval variable, the bucket hydraulic cylinder push rod manufacturing accuracy is relatively high, and the density ⁇ pushrod sample data is relatively complete, so it is described as a generalized beta distribution.
- the driving oil pressure p in the bucket hydraulic cylinder is described as a bounded probability variable;
- ⁇ pushrod and p are described in a bounded form using random variables that obey the generalized beta distribution (GBeta distribution). Taking the probability uncertainty p as an example, the specific operations are as follows:
- the uncertainty parameters are the midpoint and radius of the interval; for bounded probability variables, the uncertainty parameters are the mean and standard deviation;
- the maximum digging torque during the work process of the manipulator affected by the range and bounded probability uncertainty is used as the optimization objective function, and the maximum allowable
- the value of the total weight of the mechanism and the maximum working angle of the bucket are used as the constraint performance function, and a robust optimization design model of the manipulator based on the mixed uncertainty of interval and bounded probability is established:
- d (l FG , ⁇ GFQ ,l NQ , ⁇ NQF ,l MN ,l MK ,l KQ ,L min , ⁇ ) is the design vector;
- X (p, ⁇ pushrod ) is the bounded probability type Determine the vector;
- U (l FQ , ⁇ linkage ) is the interval type uncertain vector;
- l GN (d, X, U) is the distance between the hinge points G and N, which can be obtained by solving the triangle; They are the mean value of the midpoint of the change interval of the target performance function M(d, X, U), the standard deviation of the midpoint, the mean value of the radius, and the standard of the radius under the combined influence of the bounded probability uncertainty vector X and the interval uncertainty vector U Bad in versus
- the purpose of adding the minus sign before is to convert the current maximum optimization problem to the standard minimum optimization problem;
- the objective performance function M(d,X,U) is the maximum digging moment during the working process of the manipulator
- M L (d, ⁇ X ), M R (d, ⁇ X ), M C (d, ⁇ X ), M W (d, ⁇ X ) do not contain any uncertainty, and their values are all real numbers ;
- the mean vector ⁇ X in M C (d, ⁇ X ) and M W (d, ⁇ X ) is reduced to a bounded probability uncertainty vector X.
- the bounded probability is not Determine the probability distribution range of the vector X to sample and calculate the target performance function value corresponding to each sampling point.
- the target performance function of each sampling point does not contain any uncertainty, and its value is a real number; then Monte Carlo The method calculates the mean value of the midpoint of the change interval of the target performance function M(d,X,U) under the joint influence of the bounded probability uncertainty vector X and the interval uncertainty vector U Standard deviation of midpoint Mean radius Standard deviation from radius
- the genetic algorithm parameters are set as follows: the maximum evolution algebra is 150, the population size is 200, the crossover coefficient is 0.99, the variation coefficient is 0.02, the algorithm convergence condition is 1E-5, the current iteration number of the genetic algorithm is set to 1, and the initial population of the genetic algorithm is generated for:
- d 1 (228.024,67.972,117.406,10.673,173.740,192.364,200.362,600.760,1.384),
- d 200 (221.804,72.912,118.150,8.503,185.726,203.714,195.065,593.330,1.419);
- the following takes the first iteration process as an example to illustrate the direct solution process of the robust optimization design model of the robotic arm based on the genetic algorithm.
- sort 98 partially infeasible individuals in descending order of their corresponding total feasible robustness index S from large to small. The smaller the value of S, the worse the robustness of the constraint performance function of the corresponding partially infeasible individuals.
- steps 3.2) to 3.6) are performed until the maximum evolutionary generation or convergence condition is reached.
- the final optimization results are as follows: the target performance index reaches the convergence threshold at the 32nd iteration, and the optimal design vector corresponding to the individual with the largest fitness in this iteration is:
- the maximum excavating moment of the manipulator arm corresponding to the optimal design vector is:
- the total weight of the robotic arm corresponding to the optimal design vector is
- the maximum working angle of the bucket is It satisfies the design requirements and work requirements of high-performance lightweight robustness-oriented robotic arms, thus verifying the effectiveness of the proposed method.
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Theoretical Computer Science (AREA)
- General Physics & Mathematics (AREA)
- General Engineering & Computer Science (AREA)
- Evolutionary Computation (AREA)
- Life Sciences & Earth Sciences (AREA)
- Health & Medical Sciences (AREA)
- Biophysics (AREA)
- Geometry (AREA)
- Mathematical Physics (AREA)
- Computing Systems (AREA)
- Software Systems (AREA)
- Artificial Intelligence (AREA)
- Data Mining & Analysis (AREA)
- Evolutionary Biology (AREA)
- Bioinformatics & Computational Biology (AREA)
- Bioinformatics & Cheminformatics (AREA)
- Computer Hardware Design (AREA)
- Pure & Applied Mathematics (AREA)
- Computational Mathematics (AREA)
- Mathematical Optimization (AREA)
- Mathematical Analysis (AREA)
- Computational Linguistics (AREA)
- Algebra (AREA)
- Probability & Statistics with Applications (AREA)
- Genetics & Genomics (AREA)
- Biomedical Technology (AREA)
- General Health & Medical Sciences (AREA)
- Molecular Biology (AREA)
- Physiology (AREA)
- Management, Administration, Business Operations System, And Electronic Commerce (AREA)
- Feedback Control In General (AREA)
- Complex Calculations (AREA)
Abstract
一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,包括以下步骤:考虑影响机械臂性能的区间、有界概率分布两类不确定性,并将后者描述为服从广义贝塔分布的随机变量,建立机械臂稳健优化设计模型;基于遗传算法进行直接求解:利用不确定性的有界性分析种群个体约束性能函数的稳健性,并判断个体的可行性;对可行个体,采用基于多层加密拉丁超立方采样的蒙特卡洛方法计算其目标函数的均值和标准差;进而,根据约束性能函数的总可行稳健性指数和负理想解贴近距离对当前种群个体进行排序,获取稳健最优的机械臂参数。机械臂稳健性优化模型真实反映不确定性的分布,优化过程智能高效,具有很好的工程适用性。
Description
本发明属于装备结构优化设计领域,涉及一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法。
机械臂尺寸与铰接点位置直接影响着机械臂的工作作用力矩、工作效率等工作性能指标,因此,在确定机械臂主要结构杆件的长度后,还需对机构中其余导向杆件的长度与各铰接点位置进行优化设计,以保证其工作性能。
机械臂设计、制造、运行过程中通常存在着大量的不确定性因素,这些不确定性因素会使得机械臂的工作性能偏离设计期望值,无法达到预期。影响机械臂工作性能的不确定性因素往往具有多类型的分布特性。然而,国内外现有结构稳健性优化设计研究通常只考虑概率不确定性或区间不确定性,且通常采用正态分布对概率不确定性进行描述。一方面,采用正态分布描述概率不确定性在工程中存在不合理性,即:正态分布参数在理论上可取负值与正无穷,这与实际工程中不确定性参数仅在某一范围内概率性波动的事实不符。另一方面,现有方法在对采用正态分布参数描述概率不确定性的稳健优化设计模型进行求解时,通常基于6σ稳健性设计准则进行约束性能函数的转换和稳健性评估,并引入权重因子对不确定性目标性能函数进行转换,模型转换过程中产生的误差必然导致稳健性优化设计结果不可靠,而权重因子的选择也存在很大主观性。此外,现有方法基于蒙特卡洛模拟对不确定性目标性能函数进行稳健性分析时,由于采样点分布松散,往往不能充分反映目标性能函数概率不确定性的分布特征。具体地,现有采样方式在贡献度较高的不确定性参数均值点附近的采样点密度不足,而在贡献度较低的采样边界附近的采样点密度过高,难以保证目标性能函数稳健性分析结果的准确性。
因此,十分有必要提出一种能真实反映实际工程中多类型不确定性因素分布特性的机械臂稳健性优化建模方法、能避免模型转换误差的机械臂约束性能函数稳健性准确评估方法、能有效逼近概率不确定性分布特征的目标性能函数稳健性分析技术和能有效避免设计人员主观性的稳健优化模型高效求解算法,以获得在实际运行中具有良好工作性能的机械臂设计方案。
发明内容
为解决概率区间不确定因素共存情况下机械臂的稳健性优化设计问题,本发明提供了一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法。考虑机械臂所受液压缸驱动油压、制造公差与材 料属性的区间、概率两类不确定性,并对后者采用广义贝塔分布(GBeta分布)进行描述,建立包含区间与有界概率混合不确定性的机械臂稳健优化设计模型;基于遗传算法对该稳健优化模型进行直接求解:首先对全部个体利用混合不确定性的有界性进行约束性能函数的稳健性分析,根据分析结果对当前种群的个体进行分类;对完全可行个体,进一步采用基于多层加密拉丁超立方采样的蒙特卡洛方法计算目标函数的均值和标准差;然后,基于约束性能函数的总可行稳健性指数和负理想解贴近距离对当前种群个体进行直接排序与寻优,从而,高效地解决了概率与区间混合不确定性共存情况下机械臂的稳健优化设计问题。
本发明是通过以下技术方案实现的:一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,该方法包括以下步骤:
1)考虑机械臂所受液压缸驱动油压、制造公差与材料属性的不确定性,将不确定性划分为区间和有界概率两类进行处理,并采用服从广义贝塔分布(GBeta分布)的随机变量来描述各有界概率不确定性参数,具体为:
1.1)对有界概率不确定性参数X
i,通过实验获取s个样本,构造样本集
 根据该样本集,按Eq.1计算参数X
i的取值范围、按Eq.2计算参数X
i的均值与方差:


1.2)采用广义贝塔分布描述分布在[a
i,b
i]内且均值与方差分别为
 的参数X
i,首先标准化其均值与方差如Eq.3所示:

然后,采用Eq.4计算参数X
i的广义贝塔分布的分布参数α
i,β
i:

记参数X
i服从在[a
i,b
i]内且分布参数为α
i,β
i的广义贝塔分布,即X
i~GBeta(a
i,b
i|α
i,β
i),且其概率密度函数如Eq.5所示:

式Eq.5中,
 是参数X
i的概率密度函数;Γ(·)是伽马函数;
广义贝塔分布及其概率密度函数是为避免采用正态分布的无界概率不确定性参数描述概率不确定性时所蕴含的不合理性而首次提出的描述模型,其基本原理为,保留贝塔分布在标准区间[0,1]上分布有界及其分布参数相对可控的优点,通过线性变换在标准区间与工程实际概率不确定参数的分布区间建立映射关系,以此推广有界分布。采用提出的广义贝塔分布来描述工程问题中的概率不确定性参数,除能够完整保留原不确定性参数的概率统计信息(即其均值与方差)外,还避免了不确定性参数出现不合理数值的可能性,也避免了现有基于正态分布的优化模型求解时对约束函数进行转化所产生的模型误差。
2)将受区间与有界概率混合不确定性共同影响的机械臂工作过程中的理论最大作用力矩作为优化目标,将给定最大允许值的机械臂性能指标作为约束性能函数,建立包含区间与有界概率混合不确定性的机械臂稳健优化设计模型如Eq.6所示:

式Eq.6中,d=(d
1,d
2,…,d
l)为l维设计向量,X=(X
1,X
2,…,X
m)为m维有界概率不确定向量,U=(U
1,U
2,…,U
n)为n维区间不确定向量;B
i为根据设计需求给定的区间常数,
 和
 分别为B
i的左界和右界,当
 时,区间常数B
i退化为一实数;p为约束性能函数的个数;

 分别为第i个约束性能函数g
i(d,X,U)在区间与有界概率混合不确定性共同影响下约束函数性能变化区间的左界与右界,其计算方式如下:
a)利用概率不确定性向量X的有界性将其改写为区间形式
 其中
 为有界概率型不确定参数X
i对应的区间数,a
i,b
i根据Eq.1确定;I为有界概率不确定性参数对应的区间表示形式的标记;
b)将区间参数向量U与有界概率不确定性参数向量的区间形式X
I合并成一个新的区间不确定性参数向量,记为
 则
 按Eq.7计算:

传统采用正态分布无界概率变量描述不确定性参数的方法由于无法考察不确定性参数的全部可能取值,因此在评估约束函数稳健性时,一般采用6σ转化方式来估计约束性能函数变化区间,这一过程不可避免地引入转化误差;而采用所提出的广义贝塔分布有界概率变量描述不确定性参数,本专利独创性地提出一种新的评估方法:即利用概率不确定性参数的有界性,与区间不确定性参数统一形式,从而方便地直接计算出各约束性能函数变化区间的精确左右界,大大提高了约束函数稳健性评估的准确性。
式Eq.6中,
 分别为在有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数f(d,X,U)变化区间中点的均值、中点的标准差、半径的均值与半径的标准差,其值通过以下方法计算:
A)定义
 为通过将有界概率不确定向量X中的每一个概率变量取其均值所得的常值向量,称μ
X为有界概率不确定向量X的均值向量;将目标性能函数f(d,X,U)中的有界概率不确定向量X取为均值向量μ
X,此时目标性能函数转化为仅包含区间不确定性向量U的函数f(d,μ
X,U),其函数值为区间数;
B)按Eq.8采用区间分析算法对f(d,μ
X,U)进行区间分析,获得在均值向量μ
X处目标性能函数f(d,μ
X,U)变化区间的左右界f
L(d,μ
X)、f
R(d,μ
X):

式Eq.8中,
 与
 分别为使f(d,μ
X,U)取最小与最大值的区间不确定性向量;
C)据此按Eq.9进一步计算获得在均值向量μ
X处目标性能函数f(d,μ
X,U)变化区间的中点和半径f
C(d,μ
X),f
W(d,μ
X):

式Eq.9中,f
L(d,μ
X),f
R(d,μ
X),f
C(d,μ
X),f
W(d,μ
X)均不包含任何不确定性参数,其值均为实数;
D)将f
C(d,μ
X),f
W(d,μ
X)中的μ
X还原成有界概率不确定向量X,基于多层加密拉丁超立方采样方法在有界概率不确定向量X的概率分布范围内进行采样,计算各采样点所对应的目标性能函数值,此时,各采样点对应的目标性能函数不包含任何不确定性,其值为实数;进而利用蒙特卡洛方法计算出有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数f(d,X,U)变化区间中点的均值
 中点的标准差
 半径的均值
 与半径的标准差
 具体如下:
D.1)确定m维原始采样空间D
m=[a
1,b
1]×[a
2,b
2]×…×[a
m,b
m],其中a
i,b
i(i=1,2,…,m)为按Eq.1确定的有界概率不确定参数X
i的取值边界,×为线性空间的直积算符;
D.2)通过对原始采样空间D
m进行划分、提取,构造均值邻域层采样空间
 过渡层采样空间
 形成D
m、
 三层采样空间,即:


式Eq.10、Eq.11中,
 分别为在m维均值邻域层采样空间
 的第i维的左右界点;
 分别为在m维过渡层采样空间
 的第i维的左右界点;各左右界点由Eq.12确定:

式Eq.12中,
 是有界概率不确定性参数X
i的概率累积函数
 的反函数;
D.3)设总采样规模为N,在前述三层采用空间中分别进行规模为N/3的标准拉丁超立方采样,将各层采样点进行叠加得到最终的采样点集;
D.4)利用获得的最终采样点集,通过蒙特卡洛方法计算出目标性能函数f(d,X,U)在有界概率不确定向量X与区间不确定向量U共同影响下变化区间中点的均值与标准差
 半径的均值与标准差

本专利独创性提出的多层加密拉丁超立方采样方法,保留了传统单层拉丁超立方采样的优点,同时着重考虑了对目标函数统计参数贡献度较高的均值点附近的样本分布,将原采样空间依概率累积函数,进一步划分出均值点附近的均值邻域层采样空间
 与过渡层采样空间
 使得采样更能反映目标性能函数的实际表现、减少位于有界概率不确定性参数左右界边缘的贡献度较低的样本,从而进一步提高目标性能函数稳健性评估的准确性。
3)基于遗传算法、总可行稳健性指数与负理想解贴近距离直接求解机械臂的稳健优化设计模型:
3.1)设置遗传算法参数,包括种群规模、最大迭代次数、变异和交叉概率、收敛条件等,设置遗传算法的当前迭代次数为1,并生成遗传算法的初始种群;
3.2)对当前种群中的全部个体进行约束性能函数的稳健性评估,计算设计向量d对应的总可行稳健性指数S;
3.3)按照总可行稳健性指数S对当前种群中的所有个体进行分类评估,(a)若S=p,则为完全可行个体;(b)若0<S<p,则为部分不可行个体;(c)若S=0,则为完全不可行个体;
3.4)对完全可行个体,按照前述步骤D.1)至D.4)采用基于多层加密拉丁超立方采样的蒙特卡洛方法计算其所对应目标函数的均值和标准差;
3.5)根据步骤3.3)中对当前种群个体的分类结果与步骤3.4)中对可行个体目标函数均值与标准差的计算结果,基于总可行稳健性指数和负理想解贴近距离对种群中的所有个体进行排序,得到当前种群中所有个体的适应度;
3.6)判断是否满足最大迭代次数或收敛条件,若满足,则输出适应度最大的个体所对应的设计向量作为最优解;否则,执行交叉、变异操作,迭代次数加1,生成新一代种群个体,返回步骤3.2)。
进一步地,上述步骤D.4)中,目标性能函数f(d,X,U)变化区间中点的均值
 和标准差
 的计算方式如Eq.13所示:

式Eq.13中,N为总采样规模;X
k(k=1,2,…,N)为最终采样点集中的第k个样本点;
目标性能函数f(d,X,U)变化区间半径的均值
 和标准差
 的计算方式如Eq.14所示:

式Eq.14中,N为总采样规模;X
k(k=1,2,…,N)为最终采样点集中的第k个样本点。
进一步地,上述步骤3.2)具体如下:
3.2.1)记
 与
 分别为第i个约束性能函数g
i(d,X,U)变化区间的中点与半径,定义约束性能函数g
i(d,X,U)的区间角向量为
 其模长为
 记
 与
 分别为对应第i个约束性能函数g
i(d,X,U)的给定区间常数B
i的中点与半径,定义其区间角向量为
 其模长为

3.2.2)按Eq.15计算第i个约束性能函数g
i(d,X,U)的可行稳健性指数:

式Eq.15中,S
i是第i个约束性能函数g
i(d,X,U)的可行稳健性指数;e
j=(0,1)是单位向量;tr,bia是激发因子与偏置因子,分别按Eq.16计算:

式Eq.16中,sign(·)是符号函数;
3.2.3)在计算各约束性能函数的可行稳健性指数后,按Eq.17计算个体的总可行稳健性指数S:

式Eq.17中,S
i为第i个约束性能函数g
i(d,X,U)的可行稳健性指数,p为约束性能函数的个数。
进一步地,上述步骤3.5)具体如下:
3.5.1)对于各完全可行个体,分别计算其负理想解贴近距离,并按Eq.18计算设计向量d所对应个体的负理想解贴近距离D
*(d):

式Eq.18中,各参数定义如Eq.19所示:

式Eq.19中,
 为当前种群中完全可行个体对应的所有设计向量,n
1为完全可行个体的总数;
3.5.2)对完全可行个体与部分不可行个体进行排序,使每一参与排序的个体均获得唯一的排序序号,且目标性能或约束性能稳健性越差的个体所获得排序序号越大,具体为;
a)首先,对完全可行个体按其负理想解贴近距离D
*(d)数值从大到小依次降序排序,D
*(d)数值越小,表明其对应的完全可行个体的目标性能越差,个体获得的排序序号越大,即:对满足
 的完全可行个体
 其获得的序号分别为1,2,…,n
1,其中n
1为当前种群中完全可行个体的数目,a表示个体完全可行;
b)然后,对部分不可行个体按其总可行稳健性指数S从大到小依次降序排序,S数值越小,表明其对应的部分不可行个体的约束性能函数稳健性越差,该个体获得的排序序号越大;同时,对完全可行个体与部分不可行个体两类个体排序时,需使第一个部分不可行个体的序号紧跟最后一个完全可行个体的序号,使两类个体的序号连续并保证部分不可行个体的序号均大于完全可行个体的序号,即:对满足
 的部分不可行个体
 其获得的序号分别为(n
1+1),(n
1+2),…,(n
1+n
2),其中n
2为当前种群中部分不可行个体数目,b表示个体为部分不可行;
3.5.3)计算当前种群中所有个体的适应度:a)对完全可行个体与部分不可行个体,根据步骤3.5.2)中排序所得序号计算其适应度,设置序号为i的设计向量的适应度为1/i;b)对完全不可行个体,设置其适应度为0。
本发明具有的有益效果是:
1)根据机械臂所受液压缸驱动油压、制造公差与材料属性等多源不确定性的分布特征,分别描述为区间变量或服从广义贝塔分布的有界概率变量,建立包含区间与有界概率混合不确定性变量的机械臂稳健优化设计模型,克服了现有稳健设计方法仅考虑概率变量或区间变量的不足,避免了采用正态分布随机变量描述概率不确定性因素的不合理性,所构建的机械臂稳健优化模型更符合工程实际。
2)采用服从广义贝塔分布的有界概率变量来描述概率不确定性,使得受概率区间混合不确定性影响的机械臂约束性能函数的取值也是有界概率波动的,故可直接根据约束性能函数在概率区间混合不确定性影响下波动的上下界评估其稳健性,避免了现有采用正态分布变量描述概率不确定性参数时基于6σ稳健性设计准则进行约束性能函数转换过程中所产生的简化误差,获得了更精确的约束性能函数稳健性评估结果。
3)利用基于多层加密拉丁超立方采样的蒙特卡洛模拟来分析机械臂目标性能函数的稳健性,可在不增加采样规模的前提下获取更多位于均值邻域内、贡献度较高的样本,减少位于不确定性变化范围边界、贡献度较低的样本,克服了传统拉丁超立方采样生成的采样点分布过于松散的不足,使得采样结果能更准确充分地反映概率不确定性的分布特征,进而提高了基于蒙特卡洛模拟的机械臂目标性能函数稳健性分析结果的准确性。
4)利用遗传算法对机械臂的稳健优化设计模型进行直接求解,基于所有约束性能函数的总可行稳健性指数对种群个体进行分类,结合目标性能函数的负理想解贴近距离对种群个体进行直接优劣排序与寻优,算法高效且稳定性好,且克服了现有基于概率区间混合变量的稳健优化模型求解过程中因人为指定权值而导致优化结果不确定的缺点,具有更好工程实用性。
图1是基于区间与有界概率混合不确定性的机械臂稳健优化设计方法流程图;
图2是机械臂三维模型图;
图3是机械臂机构简图。
以下结合附图和具体实例对本发明作进一步详细说明。
图中涉及信息为本发明在某型号机械臂稳健设计中的实际应用数据,图1是基于区间与有界概率混合不确定性的机械臂稳健优化设计方法流程图。
1、考虑机械臂所受的液压缸驱动油压、制造公差与材料属性的区间、概率两类不确定性,并采用服从广义贝塔分布的随机变量描述各概率不确定性参数:
1)以图2、图3所示机械臂作为研究对象,考虑制造与安装误差,将图3所示小臂长度l
FQ描述为区间变量;连杆、摇杆材料相同且制造精度要求较低,其密度ρ
linkage样本数据相对缺乏,因此将其描述为区间变量,铲斗液压缸推杆制造精度要求较高,其密度ρ
pushrod样本数据相对完备,因此将其描述为服从广义贝塔分布的有界概率变量;同时,考虑液压系统供油与其密封能力中蕴含的不确定性,将铲斗液压缸中驱动油压p描述为有界概率变量;有界概率变量ρ
pushrod与p已通过实验测量获得了充足且具有较高可靠性的样本,并已基于这些样本计算得到均值与标准差,分别为p:μ
p=16.00MPa,σ
p=0.80MPa,ρ
pushrod:μ
ρ=7.68E3kg/m
3,σ
ρ=77.00kg/m
3;首先采用服从广义贝塔分布(GBeta分布)的随机变量对ρ
pushrod与p进行有界形式的描述,以概率不确定性p为例,具体操作如下:
1.1)从概率不确定性参数p的实验样本中按Eq.1选择数值的最大与最小值,并根据工程经验圆整,确定其有研究意义的取值范围左界与右界分别为:a
p=15.00MPa,b
p=17.00MPa;计算不确定性参数p的统计信息μ
p=16.00MPa,σ
p=0.80MPa;
1.2)按Eq.3、Eq.4计算p的分布参数,得:α
p=β
p=2.10,据此记p服从定义在有界范围[15.00,17.00]内且分布参数为α
p=β
p=2.10的广义贝塔分布,即有p~GBeta(15.00,17.00|2.10,2.10);
同理可得,有界概率不确定性参数ρ
pushrod~GBeta(7.60E3,7.80E3|2.89,4.34);各不确定性的参数信息总结如表1所示。
表1 挖掘机械臂不确定参数信息

*对区间变量而言,其不确定性参数为区间中点与半径;对有界概率变量而言,其不确定性参数为其均值与标准差;
2、基于区间与有界概率混合不确定性的机械臂稳健优化设计建模:
以图3所示机械臂的铰接点G与N的位置坐标(l
FG,θ
GFQ,l
NQ,θ
NQF)、连杆长度l
MK、摇杆长度l
MN、铲斗安装长度l
KQ、铲斗液压缸最小长度L
min与其伸缩比λ为设计变量,各设计变量如表2所示;
表2 挖掘机械臂设计变量的取值范围

根据机械臂的高性能轻量化稳健性设计需求与工作范围要求,以受区间与有界概率不确定性共同影响的机械臂工作过程中的最大挖掘作用力矩作为优化目标函数,将给定最大允许值的机构总重量和铲斗最大工作转角作为约束性能函数,建立基于区间与有界概率混合不确定性的机械臂稳健优化设计模型:

s.t.


g
1(d,X,U)=L
min-(l
GN(d,X,U)+l
MN)
g
2(d,X,U)=L
min·λ
min-(l
GN(d,X,U)+l
MN)
g
3(d,X,U)=l
GN(d,X,U)-(L
min+l
MN)
g
4(d,X,U)=l
GN-(L
min·λ+l
MN)
d=(l
FG,θ
GFQ,
l
NQ,θ
NQF,l
MN,l
MK,l
KQ,L
min,λ)
X=(p,ρ
pushrod),U=(l
FQ,ρ
linkage)
式中,d=(l
FG,θ
GFQ,l
NQ,θ
NQF,l
MN,l
MK,l
KQ,L
min,λ)为设计向量;X=(p,ρ
pushrod)为有界概率型不确 定向量;U=(l
FQ,ρ
linkage)为区间型不确定向量;l
GN(d,X,U)是铰接点G、N的距离,可通过解三角形得到;
 分别为在有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数M(d,X,U)变化区间中点的均值、中点的标准差、半径的均值与半径的标准差,在
 与
 前添加负号的目的在于转换当前求最大值优化问题为标准求最小值优化问题;目标性能函数M(d,X,U)为机械臂工作过程中的最大挖掘作用力矩,可通过解析方法得到其解析表达式;
 通过以下方法计算:
2.1)将目标性能函数M(d,X,U)中的有界概率不确定向量X=(p,ρ
pushrod)取为均值向量
 此时目标性能函数转化为仅包含区间不确定性向量U=(l
FQ,ρ
linkage)的函数M(d,μ
X,U),其值为区间数;
2.2)对M(d,μ
X,U)进行区间分析,即采用区间分析算法计算出均值向量μ
X处目标性能函数M(d,μ
X,U)变化区间的上下界M
L(d,μ
X),M
R(d,μ
X);
2.3)进一步地,计算出在均值向量μ
X处目标性能函数M(d,μ
X,U)变化区间的中点和半径M
C(d,μ
X),M
W(d,μ
X),此时M
L(d,μ
X),M
R(d,μ
X),M
C(d,μ
X),M
W(d,μ
X)均不包含任何不确定性,其值均为实数;
2.4)将M
C(d,μ
X)与M
W(d,μ
X)中的均值向量μ
X还原成有界概率不确定向量X,基于多层加密拉丁超立方采样方法在有界概率不确定向量X的概率分布范围内进行采样,计算各采样点所对应的目标性能函数值,此时,各采样点的目标性能函数不包含任何不确定性,其值为实数;进而利用蒙特卡洛方法计算出有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数M(d,X,U)变化区间中点的均值
 中点的标准差
 半径的均值
 与半径的标准差

机械臂稳健优化设计模型中,
 分别为在区间与有界概率混合不确定性共同影响下机构总重量W
Total(d,X,U)变化区间的左界和右界;
 分别为 在区间与有界概率混合不确定性共同影响下最大工作转角
 变化区间左界和右界,由于原定义为约束
 不小于给定指标值,为统一约束性能函数的表示形式,故增加负号,表示为不超过给定指标值的形式;
 都是利用有界概率与区间混合不确定性的有界性计算得到的,下面以
 为例进行说明,其计算方式如下:
2.5)利用概率不确定性向量X的有界性将其改写为区间形式
 式中p
I=[a
p,b
p],
 为有界概率型不确定参数p与ρ
pushrod对应的区间数;I为有界概率不确定性区间表示形式的标记;
2.6)将区间参数向量U与有界概率不确定性参数向量的区间表示形式X
I合并成一个新的区间不确定性参数向量,记为
 则
 按下式计算:

机械臂稳健优化设计模型中,
 为几何约束函数g
i(d,X,U)(i=1,2,3,4)分别在区间与有界概率混合不确定性共同影响下,各自性能变化区间的左界和右界;
3、基于遗传算法、可行稳健性指数与负理想解贴近距离直接求解该机械臂稳健优化设计模型:
3.1)遗传算法参数设置如下:最大进化代数150,种群规模200,交叉系数0.99,变异系数0.02,算法收敛条件为1E-5,设置遗传算法的当前迭代次数为1,并生成遗传算法的初始种群为:
d
1=(228.024,67.972,117.406,10.673,173.740,192.364,200.362,600.760,1.384)、
d
2=(232.486,75.531,120.941,8.975,170.156,200.543,197.799,589.007,1.408)……
d
200=(221.804,72.912,118.150,8.503,185.726,203.714,195.065,593.330,1.419);
下面以第1次迭代过程为例说明基于遗传算法的机械臂稳健优化设计模型直接解法流程。
3.2)对当前种群中的全部个体进行约束性能函数的稳健性评估,对设计向量d对应的个体,其约 束性能函数稳健性评估的具体步骤为:
3.2.1)按步骤2.5)、2.6)中描述的方法计算当前种群中全部个体的机械臂的总重量约束函数W
Total(d,X,U)、铲斗最大工作转角约束函数
 与四个几何约束函数g
i(d,X,U)(i=1,2,3,4)性能变化区间的左界与右界为(为简明起见,在此仅展示部分个体W
Total(d,X,U)与
 的性能变化区间左右界):


对于每个约束性能函数(共六个),当前种群中全部个体均能定义其对应的区间角向量
 与

3.2.2)按Eq.10计算出每一个体对应的各约束性能函数的可行稳健性指数;
3.2.3)按Eq.12计算出每一个体对应的所有约束性能函数的总可行稳健性指数S如下:S
1=2,S
2=1.430,S
3=2,S
4=1.178,S
5=0,S
6=1.016……S
198=0,S
199=1.370,S
200=1.512;
3.3)按照总可行稳健性指数S对当前种群中的所有个体进行分类评估,即:(a)若S=p,则为完全可行个体;(b)若0<S<p,则为部分不可行个体;(c)若S=0,则为完全不可行个体;可得,完全可行个体包含d
1、d
3等(共37个),部分不可行个体包含d
2、d
4、d
6、d
199、d
200等(共98个),完全不可行个体包含d
5、d
198等(共65个);
3.4)对37个完全可行个体,按照前述步骤2.1)至2.4)采用基于多层加密拉丁超立方采样的蒙特卡洛方法计算其所对应目标函数的均值和标准差,其中,基于多层加密拉丁超立方采样的蒙特卡洛方法具体步骤为:
3.4.1)确定2维采样空间D
2=[15.00,17.00]×[7.6E3,7.8E3];
3.4.2)确定各分界点如下:

将采样空间提取、划分为三层,即原采样空间D
2、均值邻域层
 过渡层
 且有:

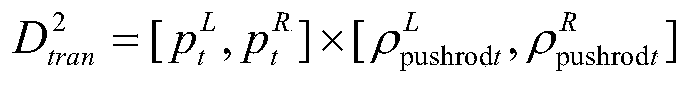
3.4.3)设总采样规模3E4,则分别在三层中实施规模为1E4的标准拉丁超立方采样,并将各层的采样结果叠加合获得最终采样点集;
3.4.4)利用获得的最终采样点集,对种群中完全可行个体的目标性能函数进行蒙特卡洛模拟,获得其目标性能函数M(d,X,U)在有界概率不确定向量X与区间不确定向量U共同影响下变化区间中点的均值与标准差、半径的均值与标准差;以目标性能函数M(d,X,U)变化区间中点的均值
 和标准差
 的计算为例,其计算方式为:


3.5)根据步骤3.3)中对当前种群个体的分类结果与步骤3.4)中对完全可行个体目标函数变化区间中点与半径的均值与标准差的计算结果,基于负理想解贴近距离对种群中所有个体进行排序,具体为:
3.5.1)首先,通过对37个完全可行个体进行比较来定义正负理想解


 接着,计算每一完全可行个体的负理想解贴近距离,D
*(d
1)=0.1292、D
*(d
3)=0.1311等;
3.5.2)对完全可行个体与部分不可行个体进行排序,使每一参与排序的个体均获得唯一的排序序号,且目标性能或约束稳健性越差的个体所获得排序序号越大,具体为;
a)首先对37个完全可行个体进行排序,按其负理想解贴近距离D
*(d)数值从大到小依次降序排序,使每一完全可行个体获得唯一排序编号;
b)接着对98个部分不可行个体按其对应的总可行稳健性指数S从大到小依次降序排序,S数值越小,表明其对应的部分不可行个体的约束性能函数稳健性越差,该个体获得的排序序号越大;同时,对完全可行个体与部分不可行个体两类个体排序时,需使第1个部分不可行个体的序号紧跟第37个完全可行个体的序号,使两类个体的序号连续并保证部分不可行个体的序号均大于完全可行个体的序号,同样使每一部分不可行个体获得唯一排序号。
3.5.3)对所有个体赋适应度值,其中完全可行个体与部分不可行个体的适应度为其排序获得的序号之倒数,完全不可行个体的适应度直接赋值为0。
3.6)判断是否达到最大进化代数或收敛条件:未达到最大迭代次数150且不满足收敛条件0.00001,因此,对当前种群个体进行交叉变异操作,生成新一批200个种群个体,迭代次数加1,进入第2次迭代。
对每一代种群中的个体,均执行步骤3.2)到3.6),直至达到最大进化代数或收敛条件。最终得到的优化结果如下:在第32次迭代时目标性能指标达到收敛阈值,该次迭代中适应度最大的个体所对应的最优设计向量为:
d
o=(231.864,65.900,120.310,10.156,173.508,192.865,202.436,601.612,1.398)
该最优设计向量对应的机械臂工作过程中的最大挖掘作用力矩为:
 该最优设计向量对应的机械臂的总重量为
 铲斗最大工作转角为
 满足面向机械臂高性能轻量化稳健性设计需求与工作要求,从而验证了所提出方法的有效性。
需要声明的是,本发明内容及具体实施方式意在证明本发明所提供技术方案的实际应用,不应解释为对本发明保护范围的限定。在本发明的精神和权利要求的保护范围内,对本发明作出的任何修改和改变,都落入本发明的保护范围。
Claims (4)
- 一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,其特征在于,该方法包括以下步骤:1)考虑机械臂所受液压缸驱动油压、制造公差与材料属性的不确定性,将不确定性划分为区间和有界概率两类进行处理,并采用服从广义贝塔分布(GBeta分布)的随机变量来描述各有界概率不确定性参数,具体为:1.1)对有界概率不确定性参数X i,通过实验获取s个样本,构造样本集根据该样本集,按Eq.1计算参数X i的取值范围、按Eq.2计算参数X i的均值与方差:


 1.2)采用广义贝塔分布描述分布在[a i,b i]内且均值与方差分别为的参数X i,首先标准化其均值与方差如Eq.3所示:

 然后,采用Eq.4计算参数X i的广义贝塔分布的分布参数α i,β i:
 记参数X i服从在[a i,b i]内且分布参数为α i,β i的广义贝塔分布,即X i~GBeta(a i,b i|α i,β i),且其概率密度函数如Eq.5所示:
 式Eq.5中,是参数X i的概率密度函数;Γ(·)是伽马函数;
 2)将受区间与有界概率混合不确定性共同影响的机械臂工作过程中的理论最大作用力矩作为优化目标,将给定最大允许值的机械臂性能指标作为约束性能函数,建立包含区间与有界概率混合不确定性的机械臂稳健优化设计模型如Eq.6所示:
 式Eq.6中,d=(d 1,d 2,…,d l)为l维设计向量,X=(X 1,X 2,…,X m)为m维有界概率不确定向量,U=(U 1,U 2,…,U n)为n维区间不确定向量;B i为根据设计需求给定的区间常数,和
 分别为B i的左界和右界,当
 时,区间常数B i退化为一实数;p为约束性能函数的个数;

 分别为第i个约束性能函数g i(d,X,U)在区间与有界概率混合不确定性共同影响下约束函数性能变化区间的左界与右界,其计算方式如下:
 a)利用概率不确定性向量X的有界性将其改写为区间形式其中
 为有界概率型不确定参数X i对应的区间数,a i,b i根据Eq.1确定;I为有界概率不确定性参数对应的区间表示形式的标记;
 b)将区间参数向量U与有界概率不确定性参数向量的区间形式X I合并成一个新的区间不确定性参数向量,记为则
 按Eq.7计算:

 式Eq.6中,分别为在有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数f(d,X,U)变化区间中点的均值、中点的标准差、半径的均值与半径的标准差,其值通过以下方法计算:
 A)定义为通过将有界概率不确定向量X中的每一个概率变量取其均值所得的常值向量,称μ X为有界概率不确定向量X的均值向量;将目标性能函数f(d,X,U)中的有界概率不确定向量X取为均值向量μ X,此时目标性能函数转化为仅包含区间不确定性向量U的函数f(d,μ X,U),其函数值为区间数;
 B)按Eq.8采用区间分析算法对f(d,μ X,U)进行区间分析,获得在均值向量μ X处目标性能函数f(d,μ X,U)变化区间的左右界f L(d,μ X)、f R(d,μ X):
 式Eq.8中,与
 分别为使f(d,μ X,U)取最小与最大值的区间不确定性向量;
 C)据此按Eq.9进一步计算获得在均值向量μ X处目标性能函数f(d,μ X,U)变化区间的中点和半径f C(d,μ X),f W(d,μ X):
 式Eq.9中,f L(d,μ X),f R(d,μ X),f C(d,μ X),f W(d,μ X)均不包含任何不确定性参数,其值均为实数;D)将f C(d,μ X),f W(d,μ X)中的μ X还原成有界概率不确定向量X,基于多层加密拉丁超立方采样方法在有界概率不确定向量X的概率分布范围内进行采样,计算各采样点所对应的目标性能函数值,此时,各采样点对应的目标性能函数不包含任何不确定性,其值为实数;进而利用蒙特卡洛方法计算出有界概率不确定向量X与区间不确定向量U共同影响下目标性能函数f(d,X,U)变化区间中点的均值中点的标准差
 半径的均值
 与半径的标准差
 具体如下:
 D.1)确定m维原始采样空间D m=[a 1,b 1]×[a 2,b 2]×…×[a m,b m],其中a i,b i(i=1,2,…,m)为按Eq.1确定的有界概率不确定参数X i的取值边界,×为线性空间的直积算符;D.2)通过对原始采样空间D m进行划分、提取,构造均值邻域层采样空间过渡层采样空间
 形成D m、
 三层采样空间,即:


 式Eq.10、Eq.11中,分别为在m维均值邻域层采样空间
 的第i维的左右界点;
 分别为在m维过渡层采样空间
 的第i维的左右界点;各左右界点由Eq.12确定:

 式Eq.12中,是有界概率不确定性参数X i的概率累积函数
 的反函数;
 D.3)设总采样规模为N,在前述三层采用空间中分别进行规模为N/3的标准拉丁超立方采样,将各层采样点进行叠加得到最终的采样点集;D.4)利用获得的最终采样点集,通过蒙特卡洛方法计算出目标性能函数f(d,X,U)在有界概率不确定向量X与区间不确定向量U共同影响下变化区间中点的均值与标准差半径的均值与标准差

 3)基于遗传算法、总可行稳健性指数与负理想解贴近距离直接求解机械臂的稳健优化设计模型:3.1)设置遗传算法参数,包括种群规模、最大迭代次数、变异和交叉概率、收敛条件等,设置遗传算法的当前迭代次数为1,并生成遗传算法的初始种群;3.2)对当前种群中的全部个体进行约束性能函数的稳健性评估,计算设计向量d对应的总可行稳健性指数S;3.3)按照总可行稳健性指数S对当前种群中的所有个体进行分类评估,(a)若S=p,则为完全可行个体;(b)若0<S<p,则为部分不可行个体;(c)若S=0,则为完全不可行个体;3.4)对完全可行个体,按照前述步骤D.1)至D.4)采用基于多层加密拉丁超立方采样的蒙特卡洛 方法计算其所对应目标函数的均值和标准差;3.5)根据步骤3.3)中对当前种群个体的分类结果与步骤3.4)中对可行个体目标函数均值与标准差的计算结果,基于总可行稳健性指数和负理想解贴近距离对种群中的所有个体进行排序,得到当前种群中所有个体的适应度;3.6)判断是否满足最大迭代次数或收敛条件,若满足,则输出适应度最大的个体所对应的设计向量作为最优解;否则,执行交叉、变异操作,迭代次数加1,生成新一代种群个体,返回步骤3.2)。
- 根据权利要求1所述的一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,其特征在于,所述步骤D.4)中,目标性能函数f(d,X,U)变化区间中点的均值和标准差
 的计算方式如Eq.13所示:

 式Eq.13中,N为总采样规模;X k(k=1,2,…,N)为最终采样点集中的第k个样本点;目标性能函数f(d,X,U)变化区间半径的均值和标准差
 的计算方式如Eq.14所示:

 式Eq.14中,N为总采样规模;X k(k=1,2,…,N)为最终采样点集中的第k个样本点。
- 根据权利要求1所述的一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,其特征在于,所述步骤3.2)具体如下:3.2.1)记与
 分别为第i个约束性能函数g i(d,X,U)变化区间的中点与半径,定义约束性能函数g i(d,X,U)的区间角向量为
 其模长为
 记
 与
 分别为对应第i个约束性能函数g i(d,X,U)的给定区间常数B i的中点与半径,定义其区间角向量为
 其模长为

 3.2.2)按Eq.15计算第i个约束性能函数g i(d,X,U)的可行稳健性指数:
 式Eq.15中,S i是第i个约束性能函数g i(d,X,U)的可行稳健性指数;e j=(0,1)是单位向量;tr,bia是激发因子与偏置因子,分别按Eq.16计算:
 式Eq.16中,sign(·)是符号函数;3.2.3)在计算各约束性能函数的可行稳健性指数后,按Eq.17计算个体的总可行稳健性指数S:
 式Eq.17中,S i为第i个约束性能函数g i(d,X,U)的可行稳健性指数,p为约束性能函数的个数。
- 根据权利要求1所述的一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法,其特征在于,所述步骤3.5)具体如下:3.5.1)对于各完全可行个体,分别计算其负理想解贴近距离,并按Eq.18计算设计向量d所对应个体的负理想解贴近距离D *(d):
 式Eq.18中,各参数定义如Eq.19所示:
 式Eq.19中,为当前种群中完全可行个体对应的所有设计向量,n 1为完全可行个体的总数;
 3.5.2)对完全可行个体与部分不可行个体进行排序,使每一参与排序的个体均获得唯一的排序序号,且目标性能或约束性能稳健性越差的个体所获得排序序号越大,具体为;a)首先,对完全可行个体按其负理想解贴近距离D *(d)数值从大到小依次降序排序,D *(d)数值越小,表明其对应的完全可行个体的目标性能越差,个体获得的排序序号越大,即:对满足的完全可行个体
 其获得的序号分别为1,2,…,n 1,其中n 1为当前种群中完全可行个体的数目,a表示个体完全可行;
 b)然后,对部分不可行个体按其总可行稳健性指数S从大到小依次降序排序,S数值越小,表明其对应的部分不可行个体的约束性能函数稳健性越差,该个体获得的排序序号越大;同时,对完全可行个体与部分不可行个体两类个体排序时,需使第一个部分不可行个体的序号紧跟最后一个完全可行个体的序号,使两类个体的序号连续并保证部分不可行个体的序号均大于完全可行个体的序号,即:对满足的部分不可行个体
 其获得的序号分别为(n 1+1),(n 1+2),…,(n 1+n 2),其中n 2为当前种群中部分不可行个体数目,b表示个体为部分不可行;
 3.5.3)计算当前种群中所有个体的适应度:a)对完全可行个体与部分不可行个体,根据步骤3.5.2)中排序所得序号计算其适应度,设置序号为i的设计向量的适应度为1/i;b)对完全不可行个体,设置其适应度为0。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2020558003A JP6908794B1 (ja) | 2019-10-17 | 2019-12-09 | 区間と有界確率との混合不確実性に基づくロボットアームのロバスト最適化設計方法 |
| US17/315,277 US20210264078A1 (en) | 2019-10-17 | 2021-05-08 | Robust optimization design method for mechanical arm based on hybrid interval and bounded probabilistic uncertainties |
| US18/959,407 US20250094668A1 (en) | 2019-10-17 | 2024-11-25 | Robust optimization design method for mechanical arm based on hybrid interval and bounded probabilistic uncertainties |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201910987618.4A CN110795836B (zh) | 2019-10-17 | 2019-10-17 | 基于区间与有界概率混合不确定性的机械臂稳健优化方法 |
| CN201910987618.4 | 2019-10-17 |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| US17/315,277 Continuation US20210264078A1 (en) | 2019-10-17 | 2021-05-08 | Robust optimization design method for mechanical arm based on hybrid interval and bounded probabilistic uncertainties |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020228310A1 true WO2020228310A1 (zh) | 2020-11-19 |
Family
ID=69439373
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2019/124148 Ceased WO2020228310A1 (zh) | 2019-10-17 | 2019-12-09 | 一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法 |
Country Status (4)
| Country | Link |
|---|---|
| US (2) | US20210264078A1 (zh) |
| JP (1) | JP6908794B1 (zh) |
| CN (1) | CN110795836B (zh) |
| WO (1) | WO2020228310A1 (zh) |
Cited By (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113733159A (zh) * | 2021-09-22 | 2021-12-03 | 伯朗特机器人股份有限公司 | 一种小臂展机器人大臂的设计方法 |
| CN113886947A (zh) * | 2021-09-13 | 2022-01-04 | 北京航空航天大学 | 一种基于迭代策略的飞行器静气弹系统输出状态量区间确定方法 |
| CN114266193A (zh) * | 2021-12-09 | 2022-04-01 | 湖南大学 | 一种重载传送链装置承载不确定性区间主成分分析方法 |
| CN114925480A (zh) * | 2022-06-17 | 2022-08-19 | 中国铁建重工集团股份有限公司 | 混合不确定性的机械力学性能分析方法、电子设备及介质 |
| CN115712977A (zh) * | 2022-08-24 | 2023-02-24 | 南京理工大学 | 一种基于Kriging代理模型辅助的齿轮减速器稳健优化设计方法 |
| CN116227355A (zh) * | 2023-03-10 | 2023-06-06 | 哈尔滨工业大学 | 一种基于高效全局优化的考虑最坏情况的稳健优化方法 |
| CN116383621A (zh) * | 2023-04-10 | 2023-07-04 | 河北工业大学 | 一种基于区间的不确定性优化方法 |
| CN117216728A (zh) * | 2023-11-09 | 2023-12-12 | 金成技术股份有限公司 | 挖掘机动臂稳定性检测方法 |
| CN117993099A (zh) * | 2024-02-01 | 2024-05-07 | 南京航空航天大学 | 一种起落架撑杆结构的优化方法 |
| CN120279737A (zh) * | 2025-03-28 | 2025-07-08 | 河北交通投资集团有限公司 | 一种考虑鲁棒性的干线交叉口协同控制方法 |
| CN121683500A (zh) * | 2025-12-11 | 2026-03-17 | 哈尔滨工程大学 | 一种考虑工程实际约束条件的设计空间内动态试验设计与高效优化方法、程序、设备及存储介质 |
Families Citing this family (35)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111475888B (zh) * | 2020-03-30 | 2022-04-12 | 浙江大学 | 自平衡电动车车架动态特性的可靠性稳健均衡设计方法 |
| CN111475976B (zh) * | 2020-03-30 | 2022-07-26 | 浙江大学 | 考虑混合不确定性的颗粒增强材料构件稳健拓扑优化方法 |
| CN111597685B (zh) * | 2020-04-14 | 2022-02-18 | 浙江大学 | 一种面向多自由度波浪能装置获能体的形状优化方法 |
| CN111967093B (zh) * | 2020-08-17 | 2022-09-02 | 上海三一重机股份有限公司 | 挖掘机的平衡布局方法、装置、电子设备和存储介质 |
| CN113032918B (zh) * | 2021-03-08 | 2022-04-19 | 浙江大学 | 一种考虑有界混合不确定性的零件结构可靠性拓扑优化设计方法 |
| WO2022188002A1 (zh) * | 2021-03-08 | 2022-09-15 | 浙江大学 | 一种复合材料支撑结构拓扑与材料协同稳健优化设计方法 |
| CN113033043B (zh) * | 2021-03-08 | 2022-05-13 | 浙江大学 | 一种复合材料支撑结构拓扑与材料协同稳健优化设计方法 |
| WO2022188001A1 (zh) | 2021-03-08 | 2022-09-15 | 浙江大学 | 一种考虑有界混合不确定性的零件结构可靠性拓扑优化设计方法 |
| US12038727B2 (en) * | 2021-03-29 | 2024-07-16 | Mitsubishi Electric Research Laboratories, Inc. | System for performing a task according to a reference trajectory |
| CN113051851B (zh) * | 2021-04-19 | 2022-09-09 | 电子科技大学 | 一种混合不确定性下的灵敏度分析方法 |
| CN113468682A (zh) * | 2021-06-16 | 2021-10-01 | 江苏大学 | 一种考虑磁材料不确定性的永磁电机稳健优化设计方法 |
| CN113447251B (zh) * | 2021-06-16 | 2022-07-26 | 南京航空航天大学 | 一种涡轮发动机支撑结构稳健性度量方法 |
| CN113987745B (zh) * | 2021-09-22 | 2024-12-03 | 东南大学 | 优化载荷样本点空间布局的抽样方法 |
| CN113919216B (zh) * | 2021-10-08 | 2024-06-28 | 北京航空航天大学 | 一种小子样条件下的参数不确定性量化度量方法 |
| CN113962145B (zh) * | 2021-10-08 | 2024-06-28 | 北京航空航天大学 | 一种区间数据样本条件下的参数不确定性量化建模方法 |
| CN114367977B (zh) * | 2021-12-08 | 2024-01-23 | 沈阳工业大学 | 一种基于rto和scfo结合的下肢康复机器人的控制方法 |
| CN114398824B (zh) * | 2021-12-20 | 2024-11-15 | 东南大学 | 基于局部代理模型的电机多目标鲁棒性优化方法 |
| CN114282309B (zh) * | 2021-12-30 | 2024-05-28 | 北京航空航天大学 | 一种基于多目标代理模型的静叶调节机构系统可靠性分析方法 |
| CN114578457B (zh) * | 2022-03-08 | 2023-05-19 | 南京市生态环境保护科学研究院 | 一种基于进化集成学习的大气污染物浓度时空预测方法 |
| CN114372332B (zh) * | 2022-03-21 | 2022-08-05 | 南京航空航天大学 | 一种基于子集模拟的多目标稳健设计方法 |
| CN115146366B (zh) * | 2022-08-01 | 2024-04-19 | 暨南大学 | 基于Direct算法和少量样本更新的结构混合可靠性分析方法 |
| CN115130249B (zh) * | 2022-08-03 | 2024-04-12 | 哈尔滨工业大学 | 一种综合考虑制造成本和质量损失的继电器容差设计方法 |
| CN116151420B (zh) * | 2022-12-02 | 2025-07-22 | 中国人民解放军海军航空大学 | 作战值班状态下舰载导弹的可靠性评估和预测方法及系统 |
| CN116127584B (zh) * | 2023-03-13 | 2024-05-14 | 西南交通大学 | 一种动态过道布置方法 |
| CN116522068B (zh) * | 2023-07-03 | 2023-09-15 | 西安羚控电子科技有限公司 | 一种试验参数生成方法和系统 |
| CN117150652B (zh) * | 2023-08-30 | 2024-04-30 | 武汉理工大学 | 一种基于船型约束空间的样本点选取方法、系统及终端 |
| JPWO2025088682A1 (zh) * | 2023-10-24 | 2025-05-01 | ||
| CN118709461B (zh) * | 2024-04-10 | 2025-07-04 | 新凤鸣集团股份有限公司 | 基于霍尔效应式张力传感器悬臂梁结构多目标优化方法 |
| CN118445992B (zh) * | 2024-04-30 | 2024-09-24 | 中南大学 | 一种基于非概率鲁棒可靠度的钻孔灌注桩稳定性设计方法 |
| CN118965054B (zh) * | 2024-06-24 | 2025-10-28 | 中国人民解放军国防科技大学 | 激光陀螺仪健康状态评估的鲁棒性分析方法和装置 |
| CN118568994B (zh) * | 2024-07-31 | 2024-10-15 | 长江勘测规划设计研究有限责任公司 | 一种卧式液压缸强度复核计算方法 |
| CN119089682B (zh) * | 2024-08-28 | 2026-05-01 | 南京工程学院 | 一种面向复杂装备响应的混合不确定性传播方法、系统、设备和介质 |
| CN120686627B (zh) * | 2025-07-01 | 2026-07-21 | 南开大学 | 一种复杂机器人系统鲁棒不变集约束稀疏化方法 |
| CN120805353B (zh) * | 2025-09-15 | 2025-11-25 | 山东大学 | 一种考虑磁芯不确定性的纳米晶高频变压器稳健设计方法 |
| CN121302869B (zh) * | 2025-09-25 | 2026-07-14 | 华北电力大学 | 一种基于6σ设计的高频变压器稳健优化方法 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2009181392A (ja) * | 2008-01-31 | 2009-08-13 | Omron Corp | モデル予測制御方法およびモデル予測制御装置 |
| CN104035337A (zh) * | 2014-06-12 | 2014-09-10 | 国电科学技术研究院 | 一种基于奇异摄动理论的柔性机械臂滑模控制设计方法 |
| CN108942936A (zh) * | 2018-07-25 | 2018-12-07 | 重庆交通大学 | 一种机器人自适应可靠性优化方法 |
| CN109732614A (zh) * | 2019-03-19 | 2019-05-10 | 合肥工业大学 | 基于约束力的scara机器人的控制设计方法及其装置及控制器 |
| CN110081046A (zh) * | 2019-05-27 | 2019-08-02 | 电子科技大学 | 一种基于反步控制的多电液伺服执行器跟踪同步控制方法 |
Family Cites Families (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP1768053A1 (en) * | 2005-09-12 | 2007-03-28 | Honda Research Institute Europe GmbH | Evolutionary search for robust solutions |
| US11389171B2 (en) * | 2006-11-21 | 2022-07-19 | David S. Goldsmith | Integrated system for the infixion and retrieval of implants |
| KR20110041950A (ko) * | 2009-10-16 | 2011-04-22 | 삼성전자주식회사 | 여유자유도 제어를 이용한 로봇의 교시 및 재현 방법 |
| US20150157350A1 (en) * | 2012-11-09 | 2015-06-11 | Graham Medical Technologies Llc | Nerve decompression scissors |
| JP6247474B2 (ja) * | 2013-08-20 | 2017-12-13 | キヤノン株式会社 | 通信装置、制御方法、及びプログラム |
| US20190143329A1 (en) * | 2013-10-01 | 2019-05-16 | Owl biomedical, Inc. | Microfabricated droplet dispensing device |
| CN103942375B (zh) * | 2014-04-11 | 2017-04-12 | 浙江大学 | 基于区间的高速压力机滑块尺寸稳健设计方法 |
| CN104537153B (zh) * | 2014-12-04 | 2017-12-08 | 北京工业大学 | 基于旋量理论的指数矩阵型机床空间误差建模及Morris全局变量敏感度分析方法 |
| CN104679956B (zh) * | 2015-02-14 | 2017-12-12 | 浙江大学 | 考虑动态特性的高速压力机底座可靠性稳健设计方法 |
| CN105095918B (zh) * | 2015-09-07 | 2018-06-26 | 上海交通大学 | 一种多机器人系统故障诊断方法 |
| CN106650917B (zh) * | 2017-01-03 | 2020-07-28 | 华南理工大学 | 一种基于并行化混沌蜂群算法的机械臂逆运动学求解方法 |
| CN107150347B (zh) * | 2017-06-08 | 2021-03-30 | 华南理工大学 | 基于人机协作的机器人感知与理解方法 |
| US11589888B2 (en) * | 2017-12-28 | 2023-02-28 | Cilag Gmbh International | Method for controlling smart energy devices |
| CN109724603A (zh) * | 2019-01-08 | 2019-05-07 | 北京航空航天大学 | 一种基于环境特征检测的室内机器人导航方法 |
| CN109992848B (zh) * | 2019-03-14 | 2020-11-13 | 浙江大学 | 一种基于负理想解贴近距离的压力机上横梁稳健优化设计方法 |
| CN110244759B (zh) * | 2019-06-05 | 2022-06-21 | 哈尔滨工程大学 | 一种基于区间优化的水下机器人时间最优路径规划方法 |
-
2019
- 2019-10-17 CN CN201910987618.4A patent/CN110795836B/zh active Active
- 2019-12-09 WO PCT/CN2019/124148 patent/WO2020228310A1/zh not_active Ceased
- 2019-12-09 JP JP2020558003A patent/JP6908794B1/ja active Active
-
2021
- 2021-05-08 US US17/315,277 patent/US20210264078A1/en not_active Abandoned
-
2024
- 2024-11-25 US US18/959,407 patent/US20250094668A1/en active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2009181392A (ja) * | 2008-01-31 | 2009-08-13 | Omron Corp | モデル予測制御方法およびモデル予測制御装置 |
| CN104035337A (zh) * | 2014-06-12 | 2014-09-10 | 国电科学技术研究院 | 一种基于奇异摄动理论的柔性机械臂滑模控制设计方法 |
| CN108942936A (zh) * | 2018-07-25 | 2018-12-07 | 重庆交通大学 | 一种机器人自适应可靠性优化方法 |
| CN109732614A (zh) * | 2019-03-19 | 2019-05-10 | 合肥工业大学 | 基于约束力的scara机器人的控制设计方法及其装置及控制器 |
| CN110081046A (zh) * | 2019-05-27 | 2019-08-02 | 电子科技大学 | 一种基于反步控制的多电液伺服执行器跟踪同步控制方法 |
Cited By (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113886947B (zh) * | 2021-09-13 | 2023-04-14 | 北京航空航天大学 | 一种基于迭代策略的飞行器静气弹系统输出状态量区间确定方法 |
| CN113886947A (zh) * | 2021-09-13 | 2022-01-04 | 北京航空航天大学 | 一种基于迭代策略的飞行器静气弹系统输出状态量区间确定方法 |
| CN113733159A (zh) * | 2021-09-22 | 2021-12-03 | 伯朗特机器人股份有限公司 | 一种小臂展机器人大臂的设计方法 |
| CN113733159B (zh) * | 2021-09-22 | 2022-12-06 | 伯朗特机器人股份有限公司 | 一种小臂展机器人大臂的设计方法 |
| CN114266193A (zh) * | 2021-12-09 | 2022-04-01 | 湖南大学 | 一种重载传送链装置承载不确定性区间主成分分析方法 |
| CN114925480B (zh) * | 2022-06-17 | 2024-09-13 | 中国铁建重工集团股份有限公司 | 混合不确定性的机械力学性能分析方法、电子设备及介质 |
| CN114925480A (zh) * | 2022-06-17 | 2022-08-19 | 中国铁建重工集团股份有限公司 | 混合不确定性的机械力学性能分析方法、电子设备及介质 |
| CN115712977A (zh) * | 2022-08-24 | 2023-02-24 | 南京理工大学 | 一种基于Kriging代理模型辅助的齿轮减速器稳健优化设计方法 |
| CN116227355A (zh) * | 2023-03-10 | 2023-06-06 | 哈尔滨工业大学 | 一种基于高效全局优化的考虑最坏情况的稳健优化方法 |
| CN116383621A (zh) * | 2023-04-10 | 2023-07-04 | 河北工业大学 | 一种基于区间的不确定性优化方法 |
| CN116383621B (zh) * | 2023-04-10 | 2026-04-28 | 河北工业大学 | 一种基于区间的不确定性优化方法 |
| CN117216728A (zh) * | 2023-11-09 | 2023-12-12 | 金成技术股份有限公司 | 挖掘机动臂稳定性检测方法 |
| CN117216728B (zh) * | 2023-11-09 | 2024-02-02 | 金成技术股份有限公司 | 挖掘机动臂稳定性检测方法 |
| CN117993099A (zh) * | 2024-02-01 | 2024-05-07 | 南京航空航天大学 | 一种起落架撑杆结构的优化方法 |
| CN120279737A (zh) * | 2025-03-28 | 2025-07-08 | 河北交通投资集团有限公司 | 一种考虑鲁棒性的干线交叉口协同控制方法 |
| CN121683500A (zh) * | 2025-12-11 | 2026-03-17 | 哈尔滨工程大学 | 一种考虑工程实际约束条件的设计空间内动态试验设计与高效优化方法、程序、设备及存储介质 |
Also Published As
| Publication number | Publication date |
|---|---|
| US20210264078A1 (en) | 2021-08-26 |
| CN110795836B (zh) | 2021-05-07 |
| US20250094668A1 (en) | 2025-03-20 |
| JP2021520557A (ja) | 2021-08-19 |
| CN110795836A (zh) | 2020-02-14 |
| JP6908794B1 (ja) | 2021-07-28 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110795836A (zh) | 一种基于区间与有界概率混合不确定性的机械臂稳健优化设计方法 | |
| CN117709555B (zh) | 一种基于变压器碳核算模型的碳排预测与评价方法和系统 | |
| CN106096127A (zh) | 含区间参数不确定性结构的稳健性优化设计方法 | |
| US12236178B2 (en) | Methods of generating circuit models and manufacturing integrated circuits using the same | |
| CN118468104A (zh) | 一种基于数字孪生的物流移动设备的故障诊断方法 | |
| CN120106307B (zh) | 基于神经网络的碳排放智能预测系统 | |
| CN104503420B (zh) | 一种基于新型fde‑elm和时延efsm的非线性过程工业故障预测方法 | |
| CN112990500A (zh) | 基于改进加权灰色关联分析的台区线损分析方法及系统 | |
| CN107295537A (zh) | 一种测评无线传感器网络可靠性的方法及系统 | |
| CN118966142B (zh) | 电源输送网络的布线参数确定方法、装置和计算机设备 | |
| CN114298854A (zh) | 一种联合学习表示和对齐的弱监督用户身份链接方法 | |
| CN116644965A (zh) | 一种项目预算的可视化分析方法及系统 | |
| CN120257684A (zh) | 堆石坝变形分析模型的参数更新方法及装置 | |
| CN109947752A (zh) | 一种基于DeepDive的自动数据清洗方法 | |
| CN113311795A (zh) | 一种基于机器学习的智能产线产品质量管控方法及系统 | |
| CN117435877A (zh) | 一种燃煤电厂碳排放在线预测方法 | |
| CN108664728A (zh) | 一种基于复杂网络动态仿真的软件模块变更影响确定方法 | |
| CN121706256A (zh) | 一种基于贝叶斯理论的航空燃油齿轮泵置信度评估方法 | |
| Zhang et al. | RSVRs based on feature extraction: a novel method for prediction of construction projects’ costs | |
| CN121615204A (zh) | 一种3d建筑模型建模方法 | |
| CN113034033B (zh) | 一种新研装备备件品种确定方法 | |
| CN113779116B (zh) | 对象排序方法、相关设备及介质 | |
| CN113239626A (zh) | 一种基于系统可靠性的传感器布局优化方法 | |
| CN119149922A (zh) | 全数据ai管控系统的智能化数据治理方法 | |
| CN117194940A (zh) | 一种基于Kendall-τ-SSA-BiLSTM的马蹄窑工作池温度预测方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| ENP | Entry into the national phase |
Ref document number: 2020558003 Country of ref document: JP Kind code of ref document: A |
|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 19928668 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 19928668 Country of ref document: EP Kind code of ref document: A1 |