JP6054535B2 - 歩行者モーション認識基盤の歩行者位置推定装置、及びその方法 - Google Patents
歩行者モーション認識基盤の歩行者位置推定装置、及びその方法 Download PDFInfo
- Publication number
- JP6054535B2 JP6054535B2 JP2015532951A JP2015532951A JP6054535B2 JP 6054535 B2 JP6054535 B2 JP 6054535B2 JP 2015532951 A JP2015532951 A JP 2015532951A JP 2015532951 A JP2015532951 A JP 2015532951A JP 6054535 B2 JP6054535 B2 JP 6054535B2
- Authority
- JP
- Japan
- Prior art keywords
- pedestrian
- user
- stride
- estimation
- motion
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images




Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C21/00—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00
- G01C21/10—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00 by using measurements of speed or acceleration
- G01C21/12—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00 by using measurements of speed or acceleration executed aboard the object being navigated; Dead reckoning
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01B—MEASURING LENGTH, THICKNESS OR SIMILAR LINEAR DIMENSIONS; MEASURING ANGLES; MEASURING AREAS; MEASURING IRREGULARITIES OF SURFACES OR CONTOURS
- G01B21/00—Measuring arrangements or details thereof, where the measuring technique is not covered by the other groups of this subclass, unspecified or not relevant
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C22/00—Measuring distance traversed on the ground by vehicles, persons, animals or other moving solid bodies, e.g. using odometers, using pedometers
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C22/00—Measuring distance traversed on the ground by vehicles, persons, animals or other moving solid bodies, e.g. using odometers, using pedometers
- G01C22/006—Pedometers
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C23/00—Combined instruments indicating more than one navigational value, e.g. for aircraft; Combined measuring devices for measuring two or more variables of movement, e.g. distance, speed or acceleration
Landscapes
- Engineering & Computer Science (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Aviation & Aerospace Engineering (AREA)
- Navigation (AREA)
- Measurement Of Distances Traversed On The Ground (AREA)
- Traffic Control Systems (AREA)
Description
歩行者が室内でモバイル機器を携帯して移動するときに、様々なモーションが発生することになる。様々なモーションの一例として、停止、歩き、走り、電話受け、モバイル機器をポケットに入れて歩くことなどが挙げられる。
前述のパターン認識を用いて歩行者の特定のモーションを認識することになる。
Claims (17)
- 歩行者位置推定方法であって、
停止、歩き、走り、電話受け及び端末機をポケットに入れて歩くことを含む歩行者の複数のモーションであって、モーションの軸が変化する歩行者の複数のモーションの中で、特定のモーションを認識するステップと、
複数のモーションのそれぞれに対する固有の歩行者推測航法技術(PDR)のうち前記認識された特定のモーションに対応する固有の歩行者推測航法技術(PDR)を行うステップと、
前記行われた固有の歩行者推測航法技術(PDR)によって歩行者の位置を推定するステップと、
を含んでなる歩行者モーション認識基盤の歩行者位置推定方法。 - 前記歩行者の様々な動きの中で、特定のモーションを認識するステップは、ユーザ端末に内蔵されたセンサからの信号に基づいたパターン認識によることを特徴とする請求項1に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- 前記パターン認識は、サーバを用いたクラウド方式または端末自体の方式であることを特徴とする請求項2に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- 前記固有の歩行者推測航法技術(PDR)は、歩数推定、歩幅推定及び方向推定の順序で行われることを特徴とする請求項1から請求項3のいずれかに記載の歩行者モーション認識基盤の歩行者位置推定方法。
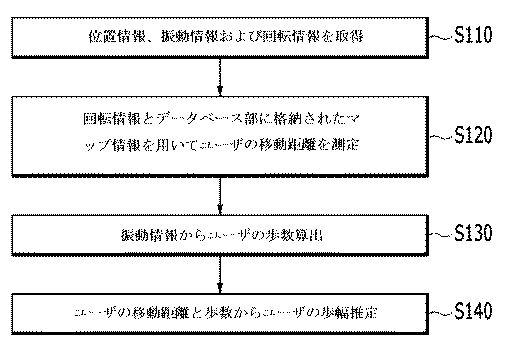
- 前記歩幅推定は、
ユーザの位置情報、振動情報及び回転情報を取得するステップと、
前記回転情報及び地理情報を用いてユーザの移動距離を測定するステップと、
前記振動情報を用いて前記ユーザの移動距離に対応するユーザの歩数を算出するステップと、
前記測定されたユーザの移動距離と前記ユーザの歩数を用いてユーザの歩幅を推定するステップと、
を含んで構成されることを特徴とする請求項4に記載の歩行者モーション認識基盤の歩行者位置推定方法。 - 前記ユーザの移動距離を測定するステップにおいて、
ユーザが特定のコーナーを回る第1の瞬間とその次のコーナーを回る第2の瞬間に測定された回転情報を特異点として用いて地理情報からユーザの実際の移動距離を測定することを特徴とする請求項5に記載の歩行者モーション認識基盤の歩行者位置推定方法。 - 前記振動情報に含まれるグラフ形の出力波形に基づいて、出力波形の最大値の間の時間を1歩と認識したり、または出力波形の最小値の間の時間を1歩と認識することを特徴とする請求項5に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- 前記ユーザの歩数を算出するステップは、出力波形が正の値から負の値に交差する点の間の時間を1歩と認識したり、または出力波形が負の値から正の値に交差する点の間の時間を1歩と認識することを特徴とする請求項5に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- 前記ユーザの歩幅と前記回転情報を用いてユーザの位置を推定するステップをさらに含むことを特徴とする請求項5に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- 前記ユーザの歩幅を推定するステップにおいて、推定されたユーザの前記歩幅の形態は、ゆっくりと歩く歩幅、通常歩く歩幅、速く歩く歩幅、走る歩幅のいずれか1つ以上を含んでなることを特徴とする請求項5に記載の歩行者モーション認識基盤の歩行者位置推定方法。
- プログラムを含む歩行者位置推定装置において、
前記プログラムは、停止、歩き、走り、電話受け及び端末機をポケットに入れて歩くことを含む歩行者の複数のモーションであって、モーションの軸が変化する歩行者の複数のモーションのそれぞれに対応する複数の固有歩行者推測航法技術(PDR)のアルゴリズムを含んでなり、
前記歩行者の複数のモーションのうち認識された特定のモーションに応じて、これに対応する特定の固有の歩行者推測航法技術(PDR)が行われることを特徴とする歩行者モーション認識基盤の歩行者位置推定装置。 - 前記歩行者の様々なモーションの中で、特定のモーションの認識は、ユーザ端末に内蔵されたセンサからの信号に基づいたパターン認識によることを特徴とする請求項11に記載の歩行者モーション認識基盤の歩行者位置推定装置。
- 前記パターン認識は、サーバを用いたクラウド方式または端末自体の方式であることを特徴とする請求項12に記載の歩行者モーション認識基盤の歩行者位置推定装置。
- 前記固有の歩行者推測航法技術(PDR)は、歩数推定、歩幅推定及び方向推定の順序で行われることを特徴とする請求項11から請求項13のいずれかに記載の歩行者モーション認識基盤の歩行者位置推定装置。
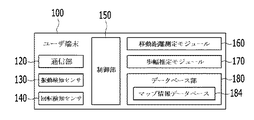
- 前記歩幅推定は、
ユーザの歩行から振動情報を検出する振動検知センサと、
前記ユーザの歩行から回転情報を検出する回転検知センサと、
地理情報を格納するデータベース部と、
前記回転情報および前記地理情報を用いてユーザの移動距離を測定する移動距離測定モジュールと、
前記振動情報を用いてユーザの歩数を算出する歩数算出モジュールと、
前記移動距離の測定モジュールで測定されたユーザの移動距離と前記歩数算出モジュールで算出されたユーザの歩数を用いてユーザの歩幅を推定する歩幅推定モジュールと、
前記データベース部、移動距離測定モジュール、歩数算出モジュール及び歩幅推定モジュールの動作を制御する制御部と、
によって行われることを特徴とする請求項14に記載の歩行者モーション認識基盤の歩行者位置推定装置。 - 前記歩幅推定モジュールで推定されたユーザの歩幅、前記振動情報および前記回転情報を用いてユーザの位置を推定する位置推定モジュールをさらに含むことを特徴とする請求項15に記載の歩行者モーション認識基盤の歩行者位置推定装置。
- 前記歩幅推定モジュールは、前記振動検知センサの出力波形の形態に応じて歩幅の形態を分類し、分類された歩幅の形態別に歩幅を推定することを特徴とする請求項15に記載の歩行者モーション認識基盤の歩行者位置推定装置。
Applications Claiming Priority (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR10-2012-0105371 | 2012-09-21 | ||
| KR1020120105371A KR101473653B1 (ko) | 2012-09-21 | 2012-09-21 | 보행자 모션 인식 기반 보행자 위치 추정 장치, 및 그 방법 |
| PCT/KR2013/008250 WO2014046419A1 (ko) | 2012-09-21 | 2013-09-12 | 보행자 모션 인식 기반 보행자 위치 추정 장치, 및 그 방법 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2015534643A JP2015534643A (ja) | 2015-12-03 |
| JP6054535B2 true JP6054535B2 (ja) | 2016-12-27 |
Family
ID=50341664
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2015532951A Expired - Fee Related JP6054535B2 (ja) | 2012-09-21 | 2013-09-12 | 歩行者モーション認識基盤の歩行者位置推定装置、及びその方法 |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US10557711B2 (ja) |
| JP (1) | JP6054535B2 (ja) |
| KR (1) | KR101473653B1 (ja) |
| WO (1) | WO2014046419A1 (ja) |
Families Citing this family (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US10281484B2 (en) * | 2014-05-02 | 2019-05-07 | Qualcomm Incorporated | Motion direction determination and application |
| KR101773084B1 (ko) * | 2014-09-24 | 2017-08-31 | 주식회사 에이텍정보기술 | 하이브리드 기반의 공간위치 추적시스템 |
| KR20160099981A (ko) | 2015-02-13 | 2016-08-23 | 자동차부품연구원 | 패턴을 가지는 입체표식기를 이용한 복수 사용자를 포함하는 쌍방향 인식이 가능한 가상현실 장치 |
| KR102280780B1 (ko) * | 2015-03-06 | 2021-07-22 | 삼성전자주식회사 | 모션 센서의 측정 정확도를 향상시키기 위한 전자 장치 및 그 방법 |
| KR101707878B1 (ko) | 2015-09-09 | 2017-02-17 | 한국과학기술연구원 | 복수의 영상 및 보행자 추측 항법 기술을 이용한 사용자 위치 추정 장치 및 그 방법 |
| KR102024560B1 (ko) | 2016-12-13 | 2019-09-24 | 한국전자통신연구원 | 재난 환경에서 구조를 지원하기 위한 정보 제공 방법 및 장치 |
| KR102825506B1 (ko) | 2019-01-23 | 2025-06-27 | 삼성전자주식회사 | 전자 장치 및 그 제어 방법 |
| KR101991703B1 (ko) * | 2019-04-02 | 2019-06-21 | 엘아이지넥스원 주식회사 | 보행자 위치추적시스템 및 방법 |
| TW202102392A (zh) * | 2019-07-02 | 2021-01-16 | 帷享科技股份有限公司 | 提高判斷精度及提早預警之行車安全輔助系統與方法 |
| JP2021081339A (ja) * | 2019-11-20 | 2021-05-27 | ヤフー株式会社 | 情報処理装置、情報処理方法、および情報処理プログラム |
| KR102572895B1 (ko) * | 2021-01-26 | 2023-08-31 | 숭실대학교 산학협력단 | 스마트폰의 다중 센서 및 gps 위치신호를 이용한 딥러닝 기반의 pdr 측위 장치 및 그 방법 |
| KR102489919B1 (ko) | 2022-06-03 | 2023-01-18 | 주식회사 원지랩스 | 보행 분석 방법 및 시스템 |
Family Cites Families (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0989584A (ja) | 1995-09-26 | 1997-04-04 | Honda Motor Co Ltd | 携帯用ナビゲーション装置 |
| JP3915654B2 (ja) * | 2002-10-18 | 2007-05-16 | 株式会社日立製作所 | 屋内位置検出装置及び屋内位置検出方法 |
| WO2008035827A1 (en) * | 2006-09-21 | 2008-03-27 | Jongchul Kim | Pedestrian navigation method and apparatus for using geographic information system |
| KR100800874B1 (ko) * | 2006-10-31 | 2008-02-04 | 삼성전자주식회사 | 보폭 추정 방법 및 이를 위한 휴대 단말 |
| JP2009168792A (ja) * | 2007-12-21 | 2009-07-30 | Sumitomo Electric Ind Ltd | 歩幅算出装置、歩行距離特定装置、位置特定装置、コンピュータプログラム及び歩幅算出方法 |
| WO2010007765A1 (ja) * | 2008-07-15 | 2010-01-21 | パナソニック株式会社 | 携帯端末及びその位置特定方法 |
| WO2010073688A1 (ja) * | 2008-12-26 | 2010-07-01 | オムロンヘルスケア株式会社 | 電子血圧計および血圧測定方法 |
| KR20090061019A (ko) * | 2009-03-27 | 2009-06-15 | 김종철 | 보행자용 지리정보시스템을 위한 보행항법과 장치 |
| KR101622579B1 (ko) * | 2009-09-10 | 2016-05-20 | 삼성전자주식회사 | 휴대용 단말기에서 위치 정보 서비스를 제공하기 위한 장치 및 방법 |
| US8447272B2 (en) * | 2009-11-25 | 2013-05-21 | Visa International Service Association | Authentication and human recognition transaction using a mobile device with an accelerometer |
| US8694251B2 (en) * | 2010-11-25 | 2014-04-08 | Texas Instruments Incorporated | Attitude estimation for pedestrian navigation using low cost mems accelerometer in mobile applications, and processing methods, apparatus and systems |
-
2012
- 2012-09-21 KR KR1020120105371A patent/KR101473653B1/ko not_active Expired - Fee Related
-
2013
- 2013-09-12 JP JP2015532951A patent/JP6054535B2/ja not_active Expired - Fee Related
- 2013-09-12 US US14/429,162 patent/US10557711B2/en active Active
- 2013-09-12 WO PCT/KR2013/008250 patent/WO2014046419A1/ko not_active Ceased
Also Published As
| Publication number | Publication date |
|---|---|
| WO2014046419A1 (ko) | 2014-03-27 |
| US10557711B2 (en) | 2020-02-11 |
| JP2015534643A (ja) | 2015-12-03 |
| KR20140039422A (ko) | 2014-04-02 |
| US20150308831A1 (en) | 2015-10-29 |
| KR101473653B1 (ko) | 2014-12-18 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101473653B1 (ko) | 보행자 모션 인식 기반 보행자 위치 추정 장치, 및 그 방법 | |
| Liu et al. | Cooperative relative positioning of mobile users by fusing IMU inertial and UWB ranging information | |
| Sun et al. | Indoor positioning tightly coupled Wi-Fi FTM ranging and PDR based on the extended Kalman filter for smartphones | |
| Ban et al. | Indoor positioning method integrating pedestrian Dead Reckoning with magnetic field and WiFi fingerprints | |
| CN102419180B (zh) | 一种基于惯性导航系统和wifi的室内定位方法 | |
| EP2616774B1 (en) | Indoor positioning using pressure sensors | |
| Shi et al. | A robust pedestrian dead reckoning system using low-cost magnetic and inertial sensors | |
| US20160116290A1 (en) | Simultaneous localization and mapping by using earth's magnetic fields | |
| WO2016068742A1 (ru) | Способ и система позиционирования мобильного терминала внутри зданий | |
| JP5742794B2 (ja) | 慣性航法装置及びプログラム | |
| CN103207383A (zh) | 基于单个移动节点对一静止节点进行二维无线定位的方法 | |
| CN106767828A (zh) | 一种手机室内定位解决方法 | |
| CN109725284B (zh) | 用于确定物体的运动方向的方法和系统 | |
| Lategahn et al. | Tdoa and rss based extended kalman filter for indoor person localization | |
| Giarré et al. | Improved PDR localization via UWB-anchor based on-line calibration | |
| Tarrío et al. | Fusion of RSS and inertial measurements for calibration-free indoor pedestrian tracking | |
| Huang et al. | Smartphone-based indoor position and orientation tracking fusing inertial and magnetic sensing | |
| Qian et al. | RPNOS: Reliable pedestrian navigation on a smartphone | |
| KR101523147B1 (ko) | 실내 측위 장치 및 방법 | |
| CN113325455B (zh) | 用于跟踪和确定物体的室内位置的方法和系统 | |
| Lategahn et al. | Extended Kalman filter for a low cost TDoA/IMU pedestrian localization system | |
| CN115164883A (zh) | 基于可穿戴marg传感器和蓝牙定位的混合追踪方法及系统 | |
| Naguib et al. | Scalable and accurate indoor positioning on mobile devices | |
| Lin et al. | An efficient outdoor localization method for smartphones | |
| Lategahn et al. | Robust pedestrian localization in indoor environments with an IMU aided TDoA system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20150508 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20160324 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20160329 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20160628 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20161122 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20161130 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 6054535 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| LAPS | Cancellation because of no payment of annual fees |