WO2022012156A1 - 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 - Google Patents
一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 Download PDFInfo
- Publication number
- WO2022012156A1 WO2022012156A1 PCT/CN2021/094746 CN2021094746W WO2022012156A1 WO 2022012156 A1 WO2022012156 A1 WO 2022012156A1 CN 2021094746 W CN2021094746 W CN 2021094746W WO 2022012156 A1 WO2022012156 A1 WO 2022012156A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- pendulum
- inverted pendulum
- rod
- rotating
- arm
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B13/00—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion
- G05B13/02—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric
- G05B13/04—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric involving the use of models or simulators
- G05B13/042—Adaptive control systems, i.e. systems automatically adjusting themselves to have a performance which is optimum according to some preassigned criterion electric involving the use of models or simulators in which a parameter or coefficient is automatically adjusted to optimise the performance
Definitions
- the invention relates to the field of robot optimization control, in particular to an iterative feedback tuning control of a rotating inverted pendulum and a robust optimization method thereof.
- the rotating inverted pendulum As a typical underactuated nonlinear system, the rotating inverted pendulum has the characteristics of instability, multi-variable, strong coupling, etc., and integrates the three basic disciplines of mathematics, electricity and mechanics well. Therefore, the control of the inverted pendulum system is not only of great significance, but also extremely challenging, and is highly valued by experts and scholars in control disciplines all over the world.
- the rotating inverted pendulum as the simplest model of many control objects such as robots and rocket flight attitudes, is an ideal experimental platform to verify the correctness of various control theory strategies, and builds a bridge between control theory and practical engineering applications. At the same time, as an experimental device, the structure is simple and the control effect is intuitive, and it is an ideal experimental platform for verifying various control methods.
- the type in which the pivot is rotationally moved is also called a rotary inverted pendulum.
- the pendulum is controlled by the movement of the trolley, and the swing arm drives the pendulum to rotate to maintain the upright state, and the nonlinearity is stronger.
- the rotating inverted pendulum as the controlled object, it is possible to test whether the iterative feedback tuning algorithm has the optimization ability for multi-state, nonlinear and absolutely unstable control systems.
- the control research of the rotating inverted pendulum system involves almost most of the control methods, among which the traditional control fields mainly include state feedback control, synovial control and PID control.
- the state feedback control must have an accurate model of the controlled system, and it is difficult to realize the stable control of the inverted pendulum, especially the high-order inverted pendulum under the condition of insufficient model accuracy.
- the chattering caused by the switching state of the rotating inverted pendulum restricts its application; PID control is still the most common control method.
- the multi-closed-loop PID has a good control effect on the rotary inverted pendulum with a lower order, but the multi-closed-loop PID has a better control effect than the multi-closed-loop PID.
- the basic PID its parameter tuning is more complicated.
- the inventor proposes an iterative feedback tuning control of a rotating inverted pendulum and its robust optimization method.
- a rotating inverted pendulum experimental platform based on double closed-loop control is established, and on this basis, iterative The feedback tuning algorithm optimizes the angle PD controller of the rotating inverted pendulum system.
- An iterative feedback tuning control of a rotating inverted pendulum and its robust optimization method comprising the following steps:
- Step 1 Establish the Lagrangian and state space models of the rotating inverted pendulum
- the rotating inverted pendulum system includes a base, a transmission device, a swing rod and a swing arm.
- the base is used to ensure the stability of the mechanical structure when the swing rod swings; the end of the swing arm is connected to the swing rod, and the rotation of the DC motor drives the movement of the swing rod through the transmission device;
- the angle and angular velocity of the arm are obtained through the incremental rotary encoder that comes with the DC motor; the incremental rotary encoder and the pendulum rod are connected through the coupling, and the incremental rotary encoder is driven to rotate to obtain the angle and the angle of the pendulum rod.
- r 1 is the distance from the rotation center of the arm to the connection point with the pendulum rod, is the angular velocity when the arm rotates;
- L is the length of the pendulum rod, is the angular velocity when the pendulum rod rotates;
- the kinetic energy of the pendulum rod includes the rotational kinetic energy generated by rotation and the kinetic energy generated by moving in the horizontal direction.
- the overall kinetic energy of the rotating inverted pendulum system also includes the kinetic energy of the arm driven by the DC motor, so the overall kinetic energy V of the rotating inverted pendulum system is obtained.
- H the overall potential energy of the rotating inverted pendulum system
- E the Lagrangian function
- the Lagrangian function E is:
- Equation (8) is brought into equations (9) and (10) to obtain the nonlinear model of the rotating inverted pendulum:
- the nonlinear model of the inverted pendulum needs to be linearized. It is noted that the pendulum rod is in an upright state in the stable pendulum control, so the angle of the pendulum rod is small, and sin ⁇ , cos ⁇ exists at this time ⁇ 1, then the linear model of the rotating inverted pendulum is obtained as:
- the moment of inertia J 1 , J 2 can be obtained as follows:
- r 2 is the length of the arm
- M is the mass of the arm
- ⁇ is the density of the arm and the pendulum
- Step 2 Design a rotating inverted pendulum iterative feedback tuning double closed-loop controller
- a double closed-loop controller is designed for the state space model of the rotating inverted pendulum, and the iterative feedback tuning algorithm is used to optimize the parameters of the angle PD controller.
- G is the transfer function of the controlled object
- u(t) is the controller output
- r(t) is the reference input
- y(t) is the output of the rotating inverted pendulum system
- v(t) is an external random disturbance with a mean value of zero
- the response output under the action of the feedback control system is:
- T 0 ( ⁇ ) and S 0 ( ⁇ ) are abbreviated as T 0 and S 0
- y d is defined as a given expected input signal
- the Gauss–Newton algorithm is used to calculate the ⁇ i+1 for the next iteration update:
- Step 3 Convergence analysis of iterative feedback setting angle PD controller
- condition 1 is to ensure that the estimated gradient of the performance optimization index function is unbiased
- condition 2 is that the step size sequence ⁇ i is required to converge to zero.
- the fourth step further optimization of the robust iterative feedback setting angle PD controller
- the IFT algorithm relies on experience to select weight values such as ⁇ .
- ⁇ weight values
- the physical meanings of various performance metrics are not the same, and the operating environments are not consistent, the value ranges between them are very different.
- the same system relying on experience performance metric selected weighting factors do not have universal ⁇ , considering the range between the various performance metrics, build a cofactor L i, L i is a co-factor performance metric taken between Ratio of value ranges:
- the iterative feedback tuning algorithm obtains the Gauss–Newton gradient through three closed-loop experiments to update the parameters, which enables the control system to respond quickly to changes in the input signal and has better robustness sex.
- the invention combines the idea of iterative design and numerical optimization, links the performance index function with the I/O data, does not need to obtain the parameters of the model itself, and avoids the accuracy of the controlled object and the disturbance characteristic model in the optimization process. estimated requirements.
- a model-free method for calculating the unbiased gradient of the indicator function to the controller parameters that is, the unbiased signal of the system output differential
- Figure 1 is a schematic diagram of the swing model of the rotating inverted pendulum.
- Figure 2 is a block diagram of the double closed-loop control structure for iterative feedback tuning of the rotating inverted pendulum.
- Figure 3 is the mechanical structure diagram of the rotating inverted pendulum experimental platform.
- Figure 4 is the hardware structure diagram of the rotating inverted pendulum experimental platform.
- Figure 5 is the overall program design diagram of DSPACE.
- FIG. 6 is a schematic diagram of the trajectory of the rotating inverted pendulum pendulum rod, the criterion function and the change of the controller parameters in the iterative process.
- FIG 7 is a factor L i before and after the introduction of the auxiliary rotation inverted pendulum schematic tracking error.
- the present application discloses an iterative feedback tuning control of a rotating inverted pendulum and a robust optimization method thereof
- Step 1 Establish the Lagrangian and state space model of the rotating inverted pendulum based on the mechanical and hardware structure of the inverted pendulum;
- FIG. 1 is a schematic diagram of the swing model of the rotating inverted pendulum.
- the rotating inverted pendulum system includes a base, a transmission device, a swing rod and a swing arm.
- the base is used to ensure the mechanical structure of the swing rod.
- the end of the arm is connected to the pendulum rod, and the rotation of the DC motor drives the movement of the pendulum rod through the transmission device; the angle and angular velocity of the arm are obtained through the incremental rotary encoder that comes with the DC motor; the incremental rotation is connected through the coupling
- the rotary encoder and the pendulum rod are used to drive the incremental rotary encoder to rotate to obtain the angle and angular velocity of the pendulum rod; in the dynamic model of the rotating inverted pendulum, air resistance, friction force and tiny items are ignored to simplify the modeling process , the swing arm and the pendulum rod are regarded as a uniform long rod, and the potential energy of the rotating inverted pendulum system is set to zero when the pendulum rod is in a stable erection.
- r 1 is the distance from the rotation center of the arm to the connection point with the pendulum rod, is the angular velocity when the arm rotates;
- L is the length of the pendulum rod, is the angular velocity when the pendulum rod rotates;
- the kinetic energy of the pendulum rod includes the rotational kinetic energy generated by rotation and the kinetic energy generated by moving in the horizontal direction.
- the overall kinetic energy of the rotating inverted pendulum system also includes the kinetic energy of the arm driven by the DC motor, so the overall kinetic energy V of the rotating inverted pendulum system is obtained.
- H the overall potential energy of the rotating inverted pendulum system
- E the Lagrangian function
- the Lagrangian function E is:
- Equation (8) is brought into equations (9) and (10) to obtain the nonlinear model of the rotating inverted pendulum:
- the nonlinear model of the inverted pendulum needs to be linearized. It is noted that the pendulum rod is in an upright state in the stable pendulum control, so the angle of the pendulum rod is small, and sin ⁇ , cos ⁇ exists at this time ⁇ 1, then the linear model of the rotating inverted pendulum is obtained as:
- the moment of inertia J 1 , J 2 can be obtained as follows:
- r 2 is the length of the arm
- M is the mass of the arm
- ⁇ is the density of the arm and the pendulum.
- the state space model it can be obtained from the Lyapunov criterion and the rank criterion that the rotating inverted pendulum is an unstable but completely controllable and observable system. Therefore, the angle, angular velocity and The angle and angular velocity of the pendulum are controlled, and these parameters are completely observable.
- Step 2 Design a rotating inverted pendulum iterative feedback tuning double closed-loop controller
- T 0 ( ⁇ ) and S 0 ( ⁇ ) are abbreviated as T 0 and S 0
- y d is defined as a given expected input signal
- the Gauss–Newton algorithm is used to calculate the ⁇ i+1 for the next iteration update:
- the stable pendulum controller In order to design the stable pendulum controller to keep the pendulum rod upright and stable, first design a closed loop for the pendulum rod angle, the upright state is used as a dynamic balance, and integral control is not required, but the differential control is added to improve the control speed when the angle change rate is large, and finally the pendulum is reversed.
- the rod angle adopts PD controller; when the pendulum rod is stable and upright, the arm should remain stationary, so a closed loop is added to control the position of the arm, based on the integral of the speed, the speed of the arm adopts a PI controller; due to the closed loop of the speed It is an interference quantity of angle control, and the influence of PI controller on angle control needs to be reduced. Therefore, iterative feedback tuning algorithm is used for the tuning optimization of the PD controller parameters of the rotating inverted pendulum angle during the stable pendulum process.
- the angle IFT-PD controller is used to output the DC motor voltage.
- the swing control of the rotary inverted pendulum is realized by the position feedback of the swing arm and the speed feedback of the swing rod.
- the position feedback of the swing arm restricts the swing rod from swinging around the desired position, and the speed feedback of the swing rod makes the swing rod The swing angle is gradually increased.
- Step 3 Convergence analysis of iterative feedback setting angle PD controller
- condition 1 is to ensure that the estimated gradient of the performance optimization index function is unbiased, and condition 2 is that the step size sequence ⁇ i is required to converge to zero. ) get for:
- Step 4 Introduce auxiliary factors to further optimize the robust iterative feedback setting angle PD controller
- the IFT algorithm relies on experience to select weight values such as ⁇ .
- ⁇ weight values
- the physical meanings of various performance metrics are not the same, and the operating environments are not consistent, the value ranges between them are very different.
- the same system relying on experience performance metric selected weighting factors do not have universal ⁇ , considering the range between the various performance metrics, build a cofactor L i, L i is a co-factor performance metric taken between Ratio of value ranges:
- FIG 3 is the mechanical structure of the rotating inverted pendulum experimental platform, including the base, transmission device, DC motor, pendulum and arm and other parts
- Figure 4 is the hardware structure diagram of the rotating inverted pendulum experimental platform, the hardware structure of the rotating inverted pendulum can be obtained by DSPACE It consists of programming controller, IR2104 DC motor driver board, ETS25 absolute rotary encoder, 50V/4.9A DC motor and STM32 board for SPI communication with ETS25. DSPACE sends a PWM signal to the IR2104 DC motor driver board, and the IR2104 DC motor driver board controls the voltage and direction of the DC motor according to PWM, and further DSPACE reads the position and speed of the motor, and the motor drives the rotating arm to rotate through the transmission belt.
- the shaft drives the rotary encoder to rotate, and finally the position and speed of the pendulum rod are read by the STM32 minimum system through SPI, and sent to DSPACE through the serial port.
- the DSPACE real-time simulation system is a development and testing work platform for a control system based on MATLAB/Simulink in a real-time environment developed by the German DSPACE company. It can be seamlessly connected with MATLAB/Simulink.
- the model of DSPACE used is DS1104, which is a real-time control system based on PowerPC603 floating-point processor, and the operating frequency can reach 250MHz.
- this model includes a slave DSP subsystem based on the TMS320F204DSP microcontroller.
- RCP Rapid Control Prototyping
- specific interface connectors and connector panels provide easy access to all DSPACE input and output signals.
- This application also provides the specific design of software and hardware based on DSPACE rotating inverted pendulum:
- this patent adopts the typical control circuit of the DC motor, the H-bridge drive circuit. By controlling the on and off of the MOS tube, the magnitude of the motor voltage and the direction of the current are changed to realize the control of the DC motor.
- the angle and speed of the pendulum rod in the rotary inverted pendulum system are collected through a rotary encoder ETS25 that transmits data through an SPI signal.
- a STM32 minimum system is used as an intermediary, that is, it communicates with ETS25 through the STM32 board, and then sends the encoder signal to DSPACE through RS232 serial communication.
- the sensor it is a slave device, so it is connected to the MOSI of the STM32 microcontroller.
- the acquisition of the arm angle and speed is detected by the Hall sensor that comes with the DC motor. Since the reading program of this type of sensor is integrated on DSPACE, the reading of the angle and speed of the arm is relatively simple.
- Figure 5 is the overall program design diagram of DSPACE.
- the initial angle ⁇ 0 of the pendulum of the inverted pendulum is 0.1rad
- the trajectory sampling data of the pendulum rod is obtained, and these data are processed offline in MATLAB to update the PD controller.
- the optimization effect of the IFT algorithm is tested on this basis.
Landscapes
- Engineering & Computer Science (AREA)
- Health & Medical Sciences (AREA)
- Artificial Intelligence (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Evolutionary Computation (AREA)
- Medical Informatics (AREA)
- Software Systems (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Feedback Control In General (AREA)
Abstract
本发明公开了一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法,涉及机器人优化控制领域,该方法包括:基于倒立摆机械和硬件结构建立旋转倒立摆的拉格朗日和状态空间数学模型;设计旋转倒立摆迭代反馈整定双闭环控制器;针对迭代反馈整定PD控制器进行算法的收敛性分析;引入辅助因子对鲁棒迭代反馈整定角度PD控制器进一步优化,实现旋转倒立摆系统能够快速、高精度跟踪上期望运动轨迹;本申请的方法控制算法简单高效,不需要获取模型本身的参数,通过I/O数据驱动计算指标函数对控制器参数的无偏梯度;算法引入辅助因子,使得控制系统能够更好地响应输入信号的变化从而具有较好的鲁棒性。
Description
本发明涉及机器人优化控制领域,尤其是一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法。
旋转倒立摆作为一个典型的欠驱动非线性系统,具有不稳定、多变量、强耦合等特点,并很好的将数学、电学和力学这三门基础学科融合起来。因此,对于倒立摆系统的控制不仅意义重大,而且极具挑战,深受世界各地控制学科的专家学者的重视。除此之外,旋转倒立摆作为机器人、火箭飞行姿态等许多控制对象的最简单模型,是验证各种控制理论策略正确性的理想实验平台,并为控制理论和工程实际应用搭建了一个桥梁。同时作为一种实验装置,结构简单并且控制效果直观,是验证各种控制方法的理想实验平台。其中枢轴为旋转移动的类型又被称为旋转倒立摆,相比于直线型倒立摆通过小车运动控制摆杆,其通过旋臂带动摆杆旋转来保持直立状态,非线性更强。将旋转倒立摆作为被控对象,能够检验迭代反馈整定算法是否具有针对多状态、非线性和绝对不稳定控制系统的优化能力。
作为一种典型的被控模型,对旋转倒立摆系统的控制研究几乎涉及到了绝大部分的控制方法,其中在传统控制领域主要有状态反馈控制、滑膜控制和PID控制等。但这些方法都存在一些局限性,例如状态反馈控制必须要有被控系统的精确模型,在模型精确度不足的情况下难以实现对倒立摆尤其是高阶倒立摆的稳定控制;而滑膜控制在旋转倒立摆切换状态时引起的抖振制约了其应用;PID控制依然是最为普遍的控制方式,其中多闭环PID对阶次较低的旋转倒立摆的控制效果良好,但多闭环PID相比于基础的PID,其参数整定较为复杂。
发明内容
本发明人针对上述问题及技术需求,提出了一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法,首先建立起基于双闭环控制的旋转倒立摆实验平台,并再此基础上使用迭代反馈整定算法优化旋转倒立摆系统的角度PD控制器, 在PD控制策略框架下,基于IFT算法的基本原理、参数最优化理论和实验整定方法,根据闭环系统的性能准则函数和输入、输出信号自动整定PID控制器参数,运用Gauss-Newton算法得到PID控制器参数的最优值,引入辅助因子不断迭代性能准则函数的权重因子达到改善系统鲁棒性的目的,最终实现对旋转倒立摆的稳定控制。
本发明的技术方案如下:
一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法,包括如下步骤:
第一步:建立旋转倒立摆的拉格朗日和状态空间模型;
旋转倒立摆系统包括底座、传动装置、摆杆及旋臂,底座用于保证摆杆摆动时机械结构的稳定;旋臂末端连接摆杆,直流电机的旋转通过传动装置带动摆杆的运动;旋臂的角度及角速度则通过直流电机自带的增量式旋转编码器获取;通过联轴器连接增量式旋转编码器与摆杆,带动增量式旋转编码器旋转从而获取摆杆的角度及角速度;在构建旋转倒立摆的动力学模型中,忽略空气阻力、摩擦力及微小项以简化建模过程,把旋臂及摆杆视为均匀的长杆,设摆杆处于稳定竖立时旋转倒立摆系统的势能为零;
摆杆偏离直立位置角度α时,旋臂通过旋转β带动摆杆趋于直立位置,因此旋臂末端速度v
m为:

其中,r
1为旋臂旋转中心到与摆杆连接点的距离,
 为旋臂旋转时角速度;
由于摆杆为均匀长杆,视摆杆为一质点则得到摆杆转动速度为v
z为:

其中,L为摆杆长度,
 为摆杆旋转时角速度;
将摆杆转动速度v
z在旋臂末端速度v
m垂直方向进行分解,并以摆杆旋转平面与地面水平方向速度v
r所指方向为正方向,得到:


在旋臂末端速度v
m和地面水平方向速度v
r的共同作用下,摆杆在水平方向上的速度v
b为:

摆杆的动能包含有旋转产生的转动动能以及在水平方向上移动产生的动能,另 外旋转倒立摆系统整体动能还包含有直流电机带动的旋臂的动能,因此得到旋转倒立摆系统的整体动能V,令J
1为摆杆的转动惯量,J
2为旋臂的转动惯量,m为摆杆质量,并将式(4)及(5)带入得到:

摆杆直立时设为零势能点,H为旋转倒立摆系统整体势能,E为拉格朗日函数,则偏转α角度后势能降为:

拉格朗日函数E为:

可知旋臂旋转带动摆杆运动,无外界能力输入,令T
output为电机输出转矩,B
eq为等效粘性摩擦,得到拉格朗日方程为:


式(8)带入式(9)及(10)得到旋转倒立摆的非线性模型:


从在式(11)得到的旋转倒立摆的非线性模型中,其输入为直流电机转矩,但通常情况下以直流电机电压为控制输入,因此接下来对直流电机进行建模,最终建立以直流电机电压为输入的倒立摆非线性模型;
令I
d为直流电机电流,E
d为反电动势,并考虑传动装置的效率和齿轮比值,K
T为电机转矩系数,K
E为电机转速系数,K
g为旋臂与直流电机的齿轮比,η
g为齿轮传动效率,η
d为电机效率,U为直流电机电压,R为电枢电阻,得到:

T
output=η
dη
gK
gK
TI
d (13)
将式(12)、(13)带入式(11)中,得到以直流电机电压为输入的倒立摆非线性模型为:


为了进一步建立旋转倒立摆的状态空间模型,需要将倒立摆非线性模型进行线性化,注意到摆杆在稳摆控制中处于直立状态,因此摆杆角度较小,此时存在sinα≈α,cosα≈1,则得到旋转倒立摆线性模型为:
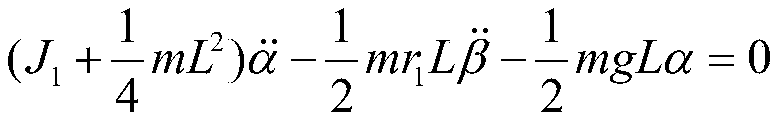

接下来以旋转倒立摆线性模型为基础来建立旋转倒立摆的状态空间模型,为了简化书写设置如下定义:

b=J
2+mr
1
2 (17)


将式(16)至(21)带入式(15)解得
 与
 为:


选取状态向量
 其中β为旋臂旋转角度,输入为直流电机电压U,得到旋转倒立摆的状态空间模型为:

其中由于摆杆及旋臂视为均匀长杆,则其转动惯量J
1、J
2可以得出:


其中,r
2为旋臂长度,M旋臂质量,ρ为旋臂和摆杆的密度;
第二步:设计旋转倒立摆迭代反馈整定双闭环控制器;
针对旋转倒立摆的状态空间模型设计双闭环控制器,使用迭代反馈整定算法优化角度PD控制器参数,若C(ρ)=[C
r(ρ) C
y(ρ)],C
r(ρ)、C
y(ρ)是线性时不变传递函数,G是被控对象的传递函数,u(t)是控制器输出,r(t)是参考输入,y(t)是旋转倒立摆系统输出,v(t)是均值为零的外部随机扰动,PID控制器参数为ρ=[K
p K
d],在此基础上反馈控制系统作用下的响应输出为:

为了简化书写,将T
0(ρ)、S
0(ρ)简写为T
0、S
0,定义y
d是给定的期望输入信号,则期望输出与实际输出之间的跟踪误差为:

对于控制器参数为ρ的固定结构PID控制器,通过最小化
 以改善反馈控制系统的跟踪控制效果,定义性能优化指标函数J(ρ)为:

其中L
y、L
u表示基于时间序列的滤波器,通常L
y=L
u=1,采样点个数为N,性能度量的权重因子为λ;IFT算法是通过最小化性能优化指标函数J(ρ)直接求得系统的PID控制器参数ρ,然后通过i次迭代逐步获取PID控制器参数ρ的最优值,ρ
i为ρ在第i次迭代中的值,在每个迭代批次中,变量y(ρ
i)和u(ρ
i)关于控制器参数ρ
i的偏导数为:


IFT算法通过在自由度控制系统中进行三次实验,以获得T
0r,T
0(r-y)的估计值,在三次实验中,前两次用来估计信号T
0,首先在第i次迭代中,第一次实验以r
i
(1)=r为输入的参考信号,y
(1)(ρ
i)为采样得到的控制系统的输出值;其次,以该两信号差值r-y
(1)(ρ
i)为第二次实验输入的参考信号r
i
(2),采样得到y
(2)(ρ
i):


第三次实验用来估计信号T
0r,以r
i
(3)=r作为输入的参考信号:

根据三次实验的控制器输出值以及旋转倒立摆系统输出值得到
 的无偏估计,同理
 可以也得到:


基于实验数据的第i次迭代的性能优化指标函数J(ρ
i)的估计梯度为:

根据性能优化指标函数J(ρ
i)的估计梯度以及上一次迭代的PID控制器参数ρ
i使用Gauss–Newton算法计算下一次迭代更新的ρ
i+1:

其中γ
i>0表示步长,R
i为正定Hessian矩阵表示优化搜索方向:

第三步:迭代反馈整定角度PD控制器的收敛性分析;
为保证算法的收敛性,条件1是保证性能优化指标函数的估计梯度是无偏的,条件2是步长序列γ
i要求能够收敛到零,为了保证条件1,由式(18)到(20)得到
 为:


基于IFT算法的实验中设定三次实验的v
i
(m),m=1,2,3是同一系统相互独立的零均值有界随机噪声,即|v
i
(m)|<C,其中假设三次实验中界限值C和随机噪声的均方值保持不变,则得到式(21)和(22)的无偏估计;
条件2需要保证算法收敛的条件通常要求步长序列γ
i的所有元素满足:

第四步:鲁棒迭代反馈整定角度PD控制器的进一步优化;
IFT算法依靠经验选择如λ一类的权重值,但由于各个性能度量之间的物理意义并不相同,运行环境也不尽一致,它们之间的取值范围相差巨大,因此若同时控制多个相同系统,依靠经验选择的性能度量的权重因子λ并不具有普适性,考虑各个性能度量之间的取值范围,构建了一个辅助因子L
i,辅助因子L
i为性能度量之间的取值范围之比:

在此基础上准则函数J(θ)修改为:

其中,
 为跟踪误差,u(θ
i)为控制器输出,
且
 和近似Hessian矩阵R
i修改为:


式中y
d,max和y
d,min为期望输出的最大值与最小值,u
max和u
min表示第i次迭代过程中控制信号在所有N个采样点中的最大值与最小值;由于这些值都是在每次迭代结束时给出,所有的采样点都会被考虑在内,因而引入辅助因子L
i使得权重因子λ在不同系统中都代表了当前迭代优化后
 与u(θ
i)权重比的最佳范围。
本发明的有益技术效果是:
针对旋转倒立摆实验平台角度PD控制器参数进行优化,迭代反馈整定算法通过三次闭环实验求取Gauss–Newton梯度进行参数更新,能够使得控制系统能够快速响应输入信号的变化从而具有较好的鲁棒性。本发明将迭代设计与数值优化的的思想相结合,将性能指标函数与I/O数据联系了起来,不需要获取模型本身的参数,避免了优化过程中对被控对象以及扰动特性模型的精确估计的要求。同时贡献出了一种计算指标函数对控制器参数的无偏梯度(也即系统输出微分的无偏信号)的无模型方法,提高了算法在复杂系统控制上的适用性。
图1为旋转倒立摆摆动模型示意图。
图2为旋转倒立摆迭代反馈整定双闭环控制结构框图。
图3为旋转倒立摆实验平台机械结构图。
图4为旋转倒立摆实验平台硬件结构图。
图5为DSPACE总体程序设计图。
图6为迭代过程中旋转倒立摆摆杆轨迹、准则函数及控制器参数变化示意图。
图7为引入辅助因子L
i前后旋转倒立摆跟踪误差示意图。
下面结合附图对本发明的具体实施方式做进一步说明。
本申请公开了一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法,
第一步:基于倒立摆机械和硬件结构建立旋转倒立摆的拉格朗日和状态空间模型;
图1为旋转倒立摆摆动模型示意图,在此基础上进行旋转倒立摆数学模型的构建,旋转倒立摆系统包括底座、传动装置、摆杆及旋臂,底座用于保证摆杆摆动时机械结构的稳定;旋臂末端连接摆杆,直流电机的旋转通过传动装置带动摆杆的运动;旋臂的角度及角速度则通过直流电机自带的增量式旋转编码器获取;通过联轴器连接增量式旋转编码器与摆杆,带动增量式旋转编码器旋转从而获取摆杆的角度及角速度;在构建旋转倒立摆的动力学模型中,忽略空气阻力、摩擦力及微小项以简化建模过程,把旋臂及摆杆视为均匀的长杆,设摆杆处于稳定竖立时旋转倒立摆系统的势能为零。结合表1所示,旋转倒立摆各物理量的含义为:
表1 旋转倒立摆各物理量意义

摆杆偏离直立位置角度α时,旋臂通过旋转β带动摆杆趋于直立位置,因此旋臂末端速度v
m为:

其中,r
1为旋臂旋转中心到与摆杆连接点的距离,
 为旋臂旋转时角速度;
由于摆杆为均匀长杆,视摆杆为一质点则得到摆杆转动速度为v
z为:

其中,L为摆杆长度,
 为摆杆旋转时角速度;
将摆杆转动速度v
z在旋臂末端速度v
m垂直方向进行分解,并以摆杆旋转平面与地面水平方向速度v
r所指方向为正方向,得到:


在旋臂末端速度v
m和地面水平方向速度v
r的共同作用下,摆杆在水平方向上的速度vb为:

摆杆的动能包含有旋转产生的转动动能以及在水平方向上移动产生的动能,另外旋转倒立摆系统整体动能还包含有直流电机带动的旋臂的动能,因此得到旋 转倒立摆系统的整体动能V,令J
1为摆杆的转动惯量,J
2为旋臂的转动惯量,m为摆杆质量,并将式(4)及(5)带入得到:

摆杆直立时设为零势能点,H为旋转倒立摆系统整体势能,E为拉格朗日函数,则偏转α角度后势能降为:

拉格朗日函数E为:

可知旋臂旋转带动摆杆运动,无外界能力输入,令T
output为电机输出转矩,B
eq为等效粘性摩擦,得到拉格朗日方程为:


式(8)带入式(9)及(10)得到旋转倒立摆的非线性模型:


从在式(11)得到的旋转倒立摆的非线性模型中,其输入为直流电机转矩,但通常情况下以直流电机电压为控制输入,因此接下来对直流电机进行建模,最终建立以直流电机电压为输入的倒立摆非线性模型;
令I
d为直流电机电流,E
d为反电动势,并考虑传动装置的效率和齿轮比值,K
T为电机转矩系数,K
E为电机转速系数,K
g为旋臂与直流电机的齿轮比,η
g为齿轮传动效率,η
d为电机效率,U为直流电机电压,R为电枢电阻,得到:

T
output=η
dη
gK
gK
TI
d (13) 将式(12)、(13)带入式(11)中,得到以直流电机电压为输入的倒立摆非线性模型为:


为了进一步建立旋转倒立摆的状态空间模型,需要将倒立摆非线性模型进行线性化,注意到摆杆在稳摆控制中处于直立状态,因此摆杆角度较小,此时存在sinα≈α,cosα≈1,则得到旋转倒立摆线性模型为:


接下来以旋转倒立摆线性模型为基础来建立旋转倒立摆的状态空间模型,为了简化书写设置如下定义:

b=J
2+mr
1
2 (17)


将式(16)至(21)带入式(15)解得
 与
 为:


选取状态向量
 其中β为旋臂旋转角度,输入为直流电机电压U,得到旋转倒立摆的状态空间模型为:

其中由于摆杆及旋臂视为均匀长杆,则其转动惯量J
1、J
2可以得出:


其中,r
2为旋臂长度,M旋臂质量,ρ为旋臂和摆杆的密度。
将如表2所示的倒立摆实际参数值带入式(16)至(25),得到旋转倒立摆的具体状态空间模型如下所示:

根据该状态空间模型,由李雅普诺夫判据及秩判据可以得到旋转倒立摆是一个不稳定的但完全能控能观的系统,因此能够通过控制直流电动机电压对旋臂的角度、角速度和摆杆的角度、角速度进行控制,并且这些参数是完全可以观测的。
表2:旋转倒立摆各实际参数

第二步:设计旋转倒立摆迭代反馈整定双闭环控制器;
结合图2所示,针对旋转倒立摆的状态空间模型设计双闭环控制器,使用迭 代反馈整定算法优化角度PD控制器参数,若C(ρ)=[C
r(ρ) C
y(ρ)],C
r(ρ)、C
y(ρ)是线性时不变传递函数,G是被控对象的传递函数,u(t)是控制器输出,r(t)是参考输入,y(t)是旋转倒立摆系统输出,v(t)是均值为零的外部随机扰动,PID控制器参数为ρ=[K
p K
d],在此基础上反馈控制系统作用下的响应输出为:

为了简化书写,将T
0(ρ)、S
0(ρ)简写为T
0、S
0,定义y
d是给定的期望输入信号,则期望输出与实际输出之间的跟踪误差为:

对于控制器参数为ρ的固定结构PID控制器,通过最小化
 以改善反馈控制系统的跟踪控制效果,定义性能优化指标函数J(ρ)为:

其中L
y、L
u表示基于时间序列的滤波器,通常L
y=L
u=1,采样点个数为N,性能度量的权重因子为λ;IFT算法是通过最小化性能优化指标函数J(ρ)直接求得系统的PID控制器参数ρ,然后通过i次迭代逐步获取PID控制器参数ρ的最优值,ρ
i为ρ在第i次迭代中的值,在每个迭代批次中,变量y(ρ
i)和u(ρ
i)关于控制器参数ρ
i的偏导数为:


IFT算法通过在自由度控制系统中进行三次实验,以获得T
0r,T
0(r-y)的估计值,在三次实验中,前两次用来估计信号T
0,首先在第i次迭代中,第一次实验以r
i
(1)=r为输入的参考信号,y
(1)(ρ
i)为采样得到的控制系统的输出值;其次,以该两信号差值r-y
(1)(ρ
i)为第二次实验输入的参考信号r
i
(2),采样得到y
(2)(ρ
i):


第三次实验用来估计信号T
0r,以r
i
(3)=r作为输入的参考信号:

根据三次实验的控制器输出值以及旋转倒立摆系统输出值得到
 的无偏估计,同理
 可以也得到:


基于实验数据的第i次迭代的性能优化指标函数J(ρ
i)的估计梯度为:

根据性能优化指标函数J(ρ
i)的估计梯度以及上一次迭代的PID控制器参数ρ
i使用Gauss–Newton算法计算下一次迭代更新的ρ
i+1:

其中γ
i>0表示步长,R
i为正定Hessian矩阵表示优化搜索方向:

为了设计稳摆控制器以维持摆杆稳定直立,首先对摆杆角度设计一个闭环,直立状态作为动态平衡,不需要积分控制,但加入微分控制提高角度变化率大时的调控速度,最终对摆杆角度采用PD控制器;摆杆稳定直立时旋臂应该保持静止,因此再次添加一个闭环对旋臂位置进行控制,基于位置是速度的积分,因此旋臂速度采用PI控制器;由于速度的闭环是角度控制的一个干扰量,PI控制器对角度控制的影响需要降低,因此迭代反馈整定算法被用于稳摆过程中旋转倒立摆角度PD控制器参数的整定优化。
将推导出来的式(26)旋转倒立摆具体状态空间模型作为控制系统未知的不确定被控对象,通过获得增量式旋转编码器采集到的摆杆实际角度与给定角度的跟踪误差,设计角度IFT-PD控制器用以输出直流电机电压。
本申请中,旋转倒立摆的起摆控制采用旋臂位置反馈以及摆杆的速度反馈实现,旋臂的位置反馈限制摆杆在期望位置周边进行摆动,而摆杆的速度反馈则使摆杆的摆角幅度逐渐变大。
第三步:迭代反馈整定角度PD控制器的收敛性分析;
为保证算法的收敛性,条件1是保证性能优化指标函数的估计梯度是无偏的,条件2是步长序列γ
i要求能够收敛到零,为了保证条件1,由式(18)到(20) 得到
 为:


基于IFT算法的实验中设定三次实验的v
i
(m),m=1,2,3是同一系统相互独立的零均值有界随机噪声,即|v
i
(m)|<C,其中假设三次实验中界限值C和随机噪声的均方值保持不变,则得到式(21)和(22)的无偏估计;
条件2需要保证算法收敛的条件通常要求步长序列γ
i的所有元素满足:

这些收敛条件的基本要求是在整个优化迭代过程中参考输入信号r(t)始终保持有界。虽然确定更新方向的矩阵R
i不会影响IFT的收敛能力,但理想选择是通过Gauss–Newton方向来加速收敛速度。因此使用Gauss–Newton优化算法可以保证算法的收敛性,使得设计的IFT算法能够很快覆盖到一个固定的优化点。该结论除了时不变性条件外,对系统的性质没有任何假设,因此结论适用于简单的PID控制器或者更复杂的控制器。
第四步:引入辅助因子对鲁棒迭代反馈整定角度PD控制器的进一步优化;
IFT算法依靠经验选择如λ一类的权重值,但由于各个性能度量之间的物理意义并不相同,运行环境也不尽一致,它们之间的取值范围相差巨大,因此若同时控制多个相同系统,依靠经验选择的性能度量的权重因子λ并不具有普适性,考虑各个性能度量之间的取值范围,构建了一个辅助因子L
i,辅助因子L
i为性能度量之间的取值范围之比:

在此基础上准则函数J(θ)修改为:

其中,
 为跟踪误差,u(θ
i)为控制器输出,
且
 和近似Hessian矩阵R
i修改为:


式中y
d,max和y
d,min为期望输出的最大值与最小值,u
max和u
min表示第i次迭代过程中控制信号在所有N个采样点中的最大值与最小值;由于这些值都是在每次迭代结束时给出,所有的采样点都会被考虑在内,因而引入辅助因子L
i使得权重因子λ在不同系统中都代表了当前迭代优化后
 与u(θ
i)权重比的最佳范围。
图3是旋转倒立摆实验平台的机械结构,包含底座、传动装置、直流电机、摆杆及旋臂等部分,图4为旋转倒立摆实验平台硬件结构图,旋转倒立摆的硬件结构由DSPACE可编程控制器、IR2104直流电机驱动板、ETS25绝对式旋转编码器、50V/4.9A的直流电机及与ETS25进行SPI通信的STM32板组成。DSPACE发出PWM信号给IR2104直流电机驱动板,而IR2104直流电机驱动板根据PWM控制直流电机的电压及转向,进一步DSPACE读取电机的位置及转速且电机通过传动带带动旋臂进行旋转,摆杆通过联轴器带动旋转编码器旋转,最后摆杆的位置及速度通过SPI由STM32最小系统读取,并通过串口发送至DSPACE。
DSPACE实时仿真系统是由德国DSPACE公司开发的一套基于MATLAB/Simulink的控制系统在实时环境下的开发及测试工作平台,它可以和MATLAB/Simulink进行无缝衔接。在本申请中,所采用的DSPACE的型号为DS1104,它是一个基于PowerPC603浮点处理器的实时控制系统,运行频率可达250MHz。为了满足对于一些高级I/O口的需求,该型号包括了一个基于TMS320F204DSP微控制器的从DSP子系统。为了快速控制原型(RCP),特定的接口连接器和连接器面板可以方便地访问DSPACE的所有输入和输出信号。
本申请还提供了基于DSPACE旋转倒立摆软件和硬件的具体设计:
基于迭代反馈整定的旋转倒立摆双闭环控制具体的鲁棒优化方案如下:
1)针对旋转倒立摆线性模型(15),设定该摆杆初始角度θ
0,初始控制信号Δu
0,期望轨迹y
d,采样周期ΔT。
2)选择角度PD控制器最初的参数ρ
1并根据式(17)设计性能优化指标J(ρ
i),给定一个阈值J
max。
3)进行三次旋转倒立摆摆动实验,实验的三次输入分别为:r
i
(1)=y
d、r
i
(2)=y
(1)(ρ
i)、r
i
(3)=y
d,第一次实验所得y
(1)(ρ
i)作为第二次实验的参考输入,第二次和第三次 实验获取控制器输入值u
(2)(ρ
i)、u
(3)(ρ
i)和系统输出值y
(2)(ρ
i)、y
(3)(ρ
i)来计算控制器参数的梯度。
4)运用第二、三次实验的结果根据式(21)和(22)计算估计梯度
 引入因子K
i获取权重因子λ的值并在式(30)基础上求取Hessian阵R
i。
5)判断系统性能优化指标J(ρ
i)是否小于J
max,若小于则转6)结束,否则重新执行步骤3)。
6)结束;
为了实现直流电机的调速及正反转,本专利采用了直流电机的典型控制电路——H桥式驱动电路。通过控制MOS管的导通及关断,改变电机电压的大小及电流的方向,实现对于直流电机的控制。
旋转倒立摆系统中的摆杆角度及速度的采集通过一款SPI信号发送数据的旋转编码器ETS25。在本次设计中,采用一块STM32最小系统作为中介,即通过STM32板与ETS25通信,再通过RS232串口通信将编码器信号发送给DSPACE。旋转编码器ETS25所使用的SPI信号数据线仅有一根,并需要5V进行上拉以提供高电平,而对于传感器来说属于从设备,因此与STM32单片机的MOSI相连。旋臂角度及速度的获取通过直流电机自带的霍尔传感器进行检测。由于DSPACE上集成了此类传感器的读取程序,因此,对于旋臂角度及速度的读取相对简单。
图5为DSPACE总体程序设计图,本申请中倒立摆的摆杆初始角度θ
0为0.1rad,PD控制器增益为θ=[150 45],将其作为θ
1,导入基于DSPACE的旋转倒立摆双闭环控制系统中以获取摆杆的轨迹采样数据,并将这些数据在MATLAB中进行离线运算进而更新PD控制器。随着迭代次数逐步增加,在此基础上来检验IFT算法的优化效果。其中迭代数i=1、i=3及i=20的旋转倒立摆摆杆的轨迹如图6(a)所示,并在这些迭代次数下准则函数J(θ
i)、k
P以及k
D的变化情况如图6(b)、(c)、(d)所示,看出随着IFT算法的不断迭代,摆杆角度的控制效果得到了明显的改善,对应的准则函数J(θ
i)的变化趋势表明输入输出误差随着迭代进行逐渐减小,PD控制器参数θ
i也最终收敛至θ
20=[325 45.7]。进一步为此分别选取λ
1=10
-4和λ
2=10
-5,然后引入随批次变化的辅助因子L
i,引入辅助因子L
i前后旋转倒立摆跟踪误差为图7所示,旋转倒立摆跟踪误差随着迭代过程的进行稳步下降,并且在引入辅助因子L
i后,跟踪误差进一步减小,表明系统 的整体控制性能进一步提升。
以上所述的仅是本申请的优选实施方式,本发明不限于以上实施例。可以理解,本领域技术人员在不脱离本发明的精神和构思的前提下直接导出或联想到的其他改进和变化,均应认为包含在本发明的保护范围之内。
Claims (1)
- 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法,其特征在于,所述方法包括:第一步:建立旋转倒立摆的拉格朗日和状态空间模型;旋转倒立摆系统包括底座、传动装置、摆杆及旋臂,所述底座用于保证所述摆杆摆动时机械结构的稳定;旋臂末端连接所述摆杆,直流电机的旋转通过所述传动装置带动所述摆杆的运动;所述旋臂的角度及角速度则通过所述直流电机自带的增量式旋转编码器获取;通过联轴器连接所述增量式旋转编码器与所述摆杆,带动所述增量式旋转编码器旋转从而获取所述摆杆的角度及角速度;在构建所述旋转倒立摆的动力学模型中,忽略空气阻力、摩擦力及微小项以简化建模过程,把所述旋臂及摆杆视为均匀的长杆,设所述摆杆处于稳定竖立时所述旋转倒立摆系统的势能为零;所述摆杆偏离直立位置角度α时,所述旋臂通过旋转β带动所述摆杆趋于直立位置,因此旋臂末端速度v m为:
 其中,r 1为旋臂旋转中心到与摆杆连接点的距离,为旋臂旋转时角速度;
 由于所述摆杆为均匀长杆,视所述摆杆为一质点则得到摆杆转动速度为v z为:
 其中,L为摆杆长度,为摆杆旋转时角速度;
 将所述摆杆转动速度v z在所述旋臂末端速度v m垂直方向进行分解,并以摆杆旋转平面与地面水平方向速度v r所指方向为正方向,得到:

 在所述旋臂末端速度v m和地面水平方向速度v r的共同作用下,所述摆杆在水平方向上的速度v b为:
 所述摆杆的动能包含有旋转产生的转动动能以及在水平方向上移动产生的动能,另外所述旋转倒立摆系统整体动能还包含有所述直流电机带动的所述旋臂 的动能,因此得到所述旋转倒立摆系统的整体动能V,令J 1为摆杆的转动惯量,J 2为旋臂的转动惯量,m为摆杆质量,并将式(4)及(5)带入得到:
 所述摆杆直立时设为零势能点,H为所述旋转倒立摆系统整体势能,E为拉格朗日函数,则偏转α角度后势能降为:
 拉格朗日函数E为:
 可知旋臂旋转带动所述摆杆运动,无外界能力输入,令T output为电机输出转矩,B eq为等效粘性摩擦,得到拉格朗日方程为:

 式(8)带入式(9)及(10)得到旋转倒立摆的非线性模型:
 从在式(11)得到的所述旋转倒立摆的非线性模型中,其输入为直流电机转矩,但通常情况下以直流电机电压为控制输入,因此接下来对所述直流电机进行建模,最终建立以所述直流电机电压为输入的倒立摆非线性模型;令I d为直流电机电流,E d为反电动势,并考虑所述传动装置的效率和齿轮比值,K T为电机转矩系数,K E为电机转速系数,K g为旋臂与直流电机的齿轮比,η g为齿轮传动效率,η d为电机效率,U为所述直流电机电压,R为电枢电阻,得到:
 T output=η dη gK gK TI d (13)将式(12)、(13)带入式(11)中,得到以所述直流电机电压为输入的所述倒立摆非线性模型为:
 为了进一步建立旋转倒立摆的状态空间模型,需要将所述倒立摆非线性模型进行线性化,注意到所述摆杆在稳摆控制中处于直立状态,因此摆杆角度较小,此时存在sinα≈α,cosα≈1,则得到旋转倒立摆线性模型为:
 接下来以所述旋转倒立摆线性模型为基础来建立所述旋转倒立摆的状态空间模型,为了简化书写设置如下定义:


 将式(16)至(21)带入式(15)解得与
 为:


 选取状态向量其中β为旋臂旋转角度,输入为所述直流电机电压U,得到所述旋转倒立摆的状态空间模型为:

 其中由于所述摆杆及旋臂视为均匀长杆,则其转动惯量J 1、J 2可以得出:
 其中,r 2为旋臂长度,M旋臂质量,ρ为旋臂和摆杆的密度;第二步:设计旋转倒立摆迭代反馈整定双闭环控制器;针对所述旋转倒立摆的状态空间模型设计所述双闭环控制器,使用迭代反馈整定算法优化角度PD控制器参数,若C(ρ)=[C r(ρ) C y(ρ)],C r(ρ)、C y(ρ)是线性时不变传递函数,G是被控对象的传递函数,u(t)是控制器输出,r(t)是参考输入,y(t)是所述旋转倒立摆系统输出,v(t)是均值为零的外部随机扰动,PID控制器参数为ρ=[K p K d],在此基础上反馈控制系统作用下的响应输出为:
 为了简化书写,将T 0(ρ)、S 0(ρ)简写为T 0、S 0,定义y d是给定的期望输入信号,则期望输出与实际输出之间的跟踪误差为:
 对于控制器参数为ρ的固定结构PID控制器,通过最小化以改善所述反馈控制系统的跟踪控制效果,定义性能优化指标函数J(ρ)为:

 其中L y、L u表示基于时间序列的滤波器,通常L y=L u=1,采样点个数为N,性能度量的权重因子为λ;IFT算法是通过最小化所述性能优化指标函数J(ρ)直接求得系统的所述PID控制器参数ρ,然后通过i次迭代逐步获取所述PID控制器参数ρ的最优值,ρ i为ρ在第i次迭代中的值,在每个迭代批次中,变量y(ρ i)和u(ρ i)关于控制器参数ρ i的偏导数为:

 所述IFT算法通过在自由度控制系统中进行三次实验,以获得T 0r,T 0(r-y)的估计值,在三次实验中,前两次用来估计信号T 0,首先在第i次迭代中,第一次实验以r i (1)=r为输入的参考信号,y (1)(ρ i)为采样得到的控制系统的输出值;其次,以两信号差值r-y (1)(ρ i)为第二次实验输入的参考信号r i (2),采样得到y (2)(ρ i):

 第三次实验用来估计信号T 0r,以r i (3)=r作为输入的参考信号:
 根据三次实验的控制器输出值以及所述旋转倒立摆系统输出值得到的无偏估计,同理
 可以也得到:

 基于实验数据的第i次迭代的所述性能优化指标函数J(ρ i)的估计梯度为:
 根据所述性能优化指标函数J(ρ i)的估计梯度以及上一次迭代的所述PID控制器参数ρ i使用Gauss–Newton算法计算下一次迭代更新的ρ i+1:
 其中γ i>0表示步长,R i为正定Hessian矩阵表示优化搜索方向:
 第三步:迭代反馈整定角度PD控制器的收敛性分析;为保证算法的收敛性,条件1是保证所述性能优化指标函数的估计梯度是无偏的,条件2是步长序列γ i要求能够收敛到零,为了保证条件1,由式(18)到(20)得到为:

 基于所述IFT算法的实验中设定三次实验的v i (m),m=1,2,3是同一系统相互独立的零均值有界随机噪声,即|v i (m)|<C,其中假设三次实验中界限值C和随机噪声的均方值保持不变,则得到式(21)和(22)的无偏估计;条件2需要保证算法收敛的条件通常要求所述步长序列γ i的所有元素满足:
 第四步:鲁棒迭代反馈整定角度PD控制器的进一步优化;所述IFT算法依靠经验选择如λ一类的权重值,但由于各个所述性能度量之间的物理意义并不相同,运行环境也不尽一致,它们之间的取值范围相差巨大,因此若同时控制多个相同系统,依靠经验选择的所述性能度量的权重因子λ并不具有普适性,考虑各个所述性能度量之间的取值范围,构建了一个辅助因子L i,所述辅助因子L i为所述性能度量之间的取值范围之比:
 在此基础上准则函数J(θ)修改为:
 其中,为跟踪误差,u(θ i)为控制器输出,
 且和近似Hessian矩阵R i修改为:


 式中y d,max和y d,min为期望输出的最大值与最小值,u max和u min表示第i次迭代过程中控制信号在所有N个采样点中的最大值与最小值;由于这些值都是在每次迭代结束时给出,所有的采样点都会被考虑在内,因而引入所述辅助因子L i使得所述权重因子λ在不同系统中都代表了当前迭代优化后与u(θ i)权重比的最佳范围。

Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010674033.X | 2020-07-14 | ||
| CN202010674033.XA CN111736471B (zh) | 2020-07-14 | 2020-07-14 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022012156A1 true WO2022012156A1 (zh) | 2022-01-20 |
Family
ID=72654521
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2021/094746 Ceased WO2022012156A1 (zh) | 2020-07-14 | 2021-05-20 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
Country Status (2)
| Country | Link |
|---|---|
| CN (1) | CN111736471B (zh) |
| WO (1) | WO2022012156A1 (zh) |
Cited By (19)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114625011A (zh) * | 2022-03-23 | 2022-06-14 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN115016282A (zh) * | 2022-06-28 | 2022-09-06 | 西安工业大学 | 一种分数阶三步法控制器及其鲁棒参数整定方法 |
| CN115236982A (zh) * | 2022-07-15 | 2022-10-25 | 合肥中科深谷科技发展有限公司 | 面向非同长二级倒立摆自起摆及其平衡控制方法 |
| CN115356932A (zh) * | 2022-08-26 | 2022-11-18 | 中国地质大学(武汉) | 伺服控制系统及前馈控制器参数整定方法 |
| CN115598967A (zh) * | 2022-11-01 | 2023-01-13 | 南栖仙策(南京)科技有限公司(Cn) | 参数整定模型训练、参数确定方法、装置、设备及介质 |
| CN115919457A (zh) * | 2022-10-08 | 2023-04-07 | 山东威高手术机器人有限公司 | 一种手术机器人双臂术前摆位平行约束投影定位方法 |
| CN116011134A (zh) * | 2022-12-07 | 2023-04-25 | 福建德日新能源汽车动力系统股份公司 | 一种倒角的深度计算方法 |
| CN116300432A (zh) * | 2023-02-14 | 2023-06-23 | 南京邮电大学 | 倒立摆系统及其控制方法 |
| CN116700323A (zh) * | 2023-05-09 | 2023-09-05 | 北京航空航天大学 | 基于鸽群层级优化的带臂无人机自抗扰控制参数整定方法 |
| CN116819952A (zh) * | 2023-02-07 | 2023-09-29 | 华东理工大学 | 一种基于混杂结构的无模型迭代学习控制方法 |
| CN117270390A (zh) * | 2023-09-25 | 2023-12-22 | 国网天津市电力公司高压分公司 | 一种双自由度观测工具的自适应控制方法 |
| CN117369246A (zh) * | 2023-12-07 | 2024-01-09 | 济南大学 | 一种基于电子阻力高位下拉器的最优鲁棒控制方法 |
| CN117389138A (zh) * | 2023-08-31 | 2024-01-12 | 北京科技大学 | 一种基于微分平坦的倒立摆改进自抗扰控制方法及系统 |
| CN117725757A (zh) * | 2023-12-29 | 2024-03-19 | 东南大学 | 数字孪生车间的总装过程虚实映射方法及系统 |
| CN118170003A (zh) * | 2024-05-14 | 2024-06-11 | 济南大学 | 一种基于改进角蜥蜴优化算法的pid参数优化方法 |
| CN118305800A (zh) * | 2024-05-11 | 2024-07-09 | 重庆大学 | 一种灵巧双指臂手机器人的鲁棒预设性能控制方法 |
| CN120370713A (zh) * | 2025-06-25 | 2025-07-25 | 青岛理工大学 | 基于持续驻留时间倒立摆系统随机通信协议滑模控制方法 |
| CN120433638A (zh) * | 2025-07-08 | 2025-08-05 | 广东敏卓机电股份有限公司 | 一种无刷直流电机的驱动方法及系统 |
| CN120540180A (zh) * | 2025-07-28 | 2025-08-26 | 睿景时代(大连)科技有限公司 | 一种基于网络通讯的倒立摆控制系统及实验方法 |
Families Citing this family (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111736471B (zh) * | 2020-07-14 | 2021-06-15 | 江南大学 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
| CN111580392B (zh) * | 2020-07-14 | 2021-06-15 | 江南大学 | 一种串联倒立摆的有限频率范围鲁棒迭代学习控制方法 |
| CN113625568A (zh) * | 2021-08-11 | 2021-11-09 | 上海交通大学 | 基于广义系统模型的倒立摆无源自适应滑模控制方法 |
| CN116643483A (zh) * | 2022-02-15 | 2023-08-25 | 北京华卓精科科技股份有限公司 | 反馈控制器优化参数获取方法和装置 |
| CN115291514B (zh) * | 2022-07-25 | 2025-08-26 | 之江实验室 | 多自由度轮式倒立摆类型机器人的二维稳定移动控制方法 |
| CN115320405B (zh) * | 2022-08-17 | 2024-09-27 | 北京航空航天大学 | 一种输入和状态饱和的电动车速度控制方法 |
| CN116107215A (zh) * | 2023-02-24 | 2023-05-12 | 华南理工大学 | 一种考虑参数不确定性的旋转倒立摆鲁棒控制方法 |
| CN116107217B (zh) * | 2023-03-10 | 2026-07-14 | 中国人民解放军海军航空大学 | 一种基于模型自适应的倒立摆角度跟踪方法 |
| CN116224800B (zh) * | 2023-03-23 | 2025-10-24 | 合肥中科深谷科技发展有限公司 | 旋转二级倒立摆的平衡控制方法、系统及存储介质 |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20080133053A1 (en) * | 2006-11-29 | 2008-06-05 | Honda Motor Co., Ltd. | Determination of Foot Placement for Humanoid Push Recovery |
| CN101866144A (zh) * | 2010-06-29 | 2010-10-20 | 北京航空航天大学 | 一种基于ITAE的Furuta摆智能控制方法 |
| JP2011014100A (ja) * | 2009-07-06 | 2011-01-20 | Toyota Central R&D Labs Inc | 倒立振子型移動体及びその制御方法 |
| CN109407513A (zh) * | 2018-12-14 | 2019-03-01 | 江南大学 | 气动人工肌肉关节的基于迭代反馈整定的跟踪控制方法 |
| CN110134011A (zh) * | 2019-04-23 | 2019-08-16 | 浙江工业大学 | 一种倒立摆自适应迭代学习反演控制方法 |
| CN111736471A (zh) * | 2020-07-14 | 2020-10-02 | 江南大学 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
Family Cites Families (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN101673354A (zh) * | 2009-06-12 | 2010-03-17 | 北京工业大学 | 操作条件反射自动机及其在仿生自主学习控制中的应用 |
| CN103823379B (zh) * | 2014-02-28 | 2017-06-13 | 北京理工大学 | 基于迭代学习的高频率角振动转台滑模控制方法 |
| EP3112959B1 (en) * | 2015-06-29 | 2021-12-22 | SUEZ Groupe | Method for detecting anomalies in a water distribution system |
| CN105334739B (zh) * | 2015-12-04 | 2017-12-19 | 东北大学 | 基于迭代学习p型学习律的fast整网控制方法 |
| CN107561929B (zh) * | 2017-07-25 | 2020-01-14 | 北京理工大学 | 一种伺服系统的无模型鲁棒自适应优化方法 |
| CN108107720B (zh) * | 2017-11-23 | 2021-03-16 | 中国南方电网有限责任公司 | 基于状态空间分析的水轮机调速器参数整定方法及系统 |
| US10522036B2 (en) * | 2018-03-05 | 2019-12-31 | Nec Corporation | Method for robust control of a machine learning system and robust control system |
| CN109856968B (zh) * | 2018-09-19 | 2022-11-08 | 湘潭大学 | 一种基于相平面模糊自调整的倒立摆系统改进型自抗扰控制方法 |
| US11007642B2 (en) * | 2018-10-23 | 2021-05-18 | X Development Llc | Machine learning methods and apparatus for automated robotic placement of secured object in appropriate location |
| CN109709802B (zh) * | 2018-12-14 | 2020-06-16 | 江南大学 | 基于迭代学习控制的有源电子梯形电路的控制方法 |
-
2020
- 2020-07-14 CN CN202010674033.XA patent/CN111736471B/zh active Active
-
2021
- 2021-05-20 WO PCT/CN2021/094746 patent/WO2022012156A1/zh not_active Ceased
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20080133053A1 (en) * | 2006-11-29 | 2008-06-05 | Honda Motor Co., Ltd. | Determination of Foot Placement for Humanoid Push Recovery |
| JP2011014100A (ja) * | 2009-07-06 | 2011-01-20 | Toyota Central R&D Labs Inc | 倒立振子型移動体及びその制御方法 |
| CN101866144A (zh) * | 2010-06-29 | 2010-10-20 | 北京航空航天大学 | 一种基于ITAE的Furuta摆智能控制方法 |
| CN109407513A (zh) * | 2018-12-14 | 2019-03-01 | 江南大学 | 气动人工肌肉关节的基于迭代反馈整定的跟踪控制方法 |
| CN110134011A (zh) * | 2019-04-23 | 2019-08-16 | 浙江工业大学 | 一种倒立摆自适应迭代学习反演控制方法 |
| CN111736471A (zh) * | 2020-07-14 | 2020-10-02 | 江南大学 | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 |
Cited By (22)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114625011A (zh) * | 2022-03-23 | 2022-06-14 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN114625011B (zh) * | 2022-03-23 | 2024-04-02 | 合肥工业大学 | 一种配电网无线通信可靠性的鲁棒控制方法 |
| CN115016282A (zh) * | 2022-06-28 | 2022-09-06 | 西安工业大学 | 一种分数阶三步法控制器及其鲁棒参数整定方法 |
| CN115236982A (zh) * | 2022-07-15 | 2022-10-25 | 合肥中科深谷科技发展有限公司 | 面向非同长二级倒立摆自起摆及其平衡控制方法 |
| CN115356932A (zh) * | 2022-08-26 | 2022-11-18 | 中国地质大学(武汉) | 伺服控制系统及前馈控制器参数整定方法 |
| CN115919457A (zh) * | 2022-10-08 | 2023-04-07 | 山东威高手术机器人有限公司 | 一种手术机器人双臂术前摆位平行约束投影定位方法 |
| CN115598967B (zh) * | 2022-11-01 | 2023-12-08 | 南栖仙策(南京)高新技术有限公司 | 参数整定模型训练、参数确定方法、装置、设备及介质 |
| CN115598967A (zh) * | 2022-11-01 | 2023-01-13 | 南栖仙策(南京)科技有限公司(Cn) | 参数整定模型训练、参数确定方法、装置、设备及介质 |
| CN116011134A (zh) * | 2022-12-07 | 2023-04-25 | 福建德日新能源汽车动力系统股份公司 | 一种倒角的深度计算方法 |
| CN116819952A (zh) * | 2023-02-07 | 2023-09-29 | 华东理工大学 | 一种基于混杂结构的无模型迭代学习控制方法 |
| CN116300432A (zh) * | 2023-02-14 | 2023-06-23 | 南京邮电大学 | 倒立摆系统及其控制方法 |
| CN116700323A (zh) * | 2023-05-09 | 2023-09-05 | 北京航空航天大学 | 基于鸽群层级优化的带臂无人机自抗扰控制参数整定方法 |
| CN117389138A (zh) * | 2023-08-31 | 2024-01-12 | 北京科技大学 | 一种基于微分平坦的倒立摆改进自抗扰控制方法及系统 |
| CN117270390A (zh) * | 2023-09-25 | 2023-12-22 | 国网天津市电力公司高压分公司 | 一种双自由度观测工具的自适应控制方法 |
| CN117369246A (zh) * | 2023-12-07 | 2024-01-09 | 济南大学 | 一种基于电子阻力高位下拉器的最优鲁棒控制方法 |
| CN117369246B (zh) * | 2023-12-07 | 2024-02-13 | 济南大学 | 一种基于电子阻力高位下拉器的最优鲁棒控制方法 |
| CN117725757A (zh) * | 2023-12-29 | 2024-03-19 | 东南大学 | 数字孪生车间的总装过程虚实映射方法及系统 |
| CN118305800A (zh) * | 2024-05-11 | 2024-07-09 | 重庆大学 | 一种灵巧双指臂手机器人的鲁棒预设性能控制方法 |
| CN118170003A (zh) * | 2024-05-14 | 2024-06-11 | 济南大学 | 一种基于改进角蜥蜴优化算法的pid参数优化方法 |
| CN120370713A (zh) * | 2025-06-25 | 2025-07-25 | 青岛理工大学 | 基于持续驻留时间倒立摆系统随机通信协议滑模控制方法 |
| CN120433638A (zh) * | 2025-07-08 | 2025-08-05 | 广东敏卓机电股份有限公司 | 一种无刷直流电机的驱动方法及系统 |
| CN120540180A (zh) * | 2025-07-28 | 2025-08-26 | 睿景时代(大连)科技有限公司 | 一种基于网络通讯的倒立摆控制系统及实验方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| CN111736471A (zh) | 2020-10-02 |
| CN111736471B (zh) | 2021-06-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111736471B (zh) | 一种旋转倒立摆的迭代反馈整定控制及其鲁棒优化方法 | |
| CN102208891B (zh) | 基于摩擦和扰动补偿的pmsm伺服系统控制方法 | |
| Akhtaruzzaman et al. | Modeling and control of a rotary inverted pendulum using various methods, comparative assessment and result analysis | |
| CN106325073B (zh) | 基于分数阶的伺服系统位置环ip控制器无模型自校正方法 | |
| CN112894821B (zh) | 基于电流法的协作机器人拖动示教控制方法、装置及设备 | |
| CN112417755A (zh) | 一种主从式手术机器人轨迹预测控制方法 | |
| CN101917150A (zh) | 永磁同步电机模糊神经网络广义逆鲁棒控制器及构造方法 | |
| CN110739893A (zh) | 一种改进自适应无轨迹卡尔曼滤波转动惯量辨识方法 | |
| CN111142404A (zh) | 一种基于压电陶瓷驱动的微定位平台及其建模与控制方法 | |
| CN105700348B (zh) | 一种基于扰动上界估计的电动转台位置跟踪控制方法 | |
| CN109873582B (zh) | 基于动态面的永磁同步电机有限时间位置跟踪控制方法 | |
| CN113093538A (zh) | 一种模块化机器人系统的非零和博弈神经-最优控制方法 | |
| CN118940437B (zh) | 一种一体伺服关节模组的校准方法及系统 | |
| CN116736749A (zh) | 构建机器人的控制器的方法和机器人 | |
| CN116638544B (zh) | 一种基于超局部模型的关节模组协同控制方法 | |
| Hu et al. | Modified linear active disturbance rejection control for uncertain robot manipulator trajectory tracking | |
| CN109884881A (zh) | 一种基于非线性pid控制技术的稳瞄伺服控制器的设计 | |
| CN104779873B (zh) | 一种用于pmsm伺服系统的预测函数控制方法 | |
| CN117290636A (zh) | 一种scara机器人不等式约束模型构建方法及模型验证方法 | |
| CN106898229A (zh) | 一种自动控制原理实验平台 | |
| CN121098169A (zh) | 基于数模联动的伺服系统速度环参数自整定方法 | |
| CN118061174B (zh) | 一种基于时延估计的误差补偿方法及控制系统 | |
| CN111293949B (zh) | 一种抗干扰电动六自由度并联机构控制方法 | |
| CN117879419A (zh) | 一种永磁同步电机的改进型无位置传感器控制方法 | |
| CN120190834A (zh) | 一种机械臂云台动态自适应控制方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21841821 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 21841821 Country of ref document: EP Kind code of ref document: A1 |