CN109353627B - Automatic conveyor of granular pesticide midbody - Google Patents
Automatic conveyor of granular pesticide midbody Download PDFInfo
- Publication number
- CN109353627B CN109353627B CN201811403194.4A CN201811403194A CN109353627B CN 109353627 B CN109353627 B CN 109353627B CN 201811403194 A CN201811403194 A CN 201811403194A CN 109353627 B CN109353627 B CN 109353627B
- Authority
- CN
- China
- Prior art keywords
- bag
- plane
- suction cup
- machine
- cylinder
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B69/00—Unpacking of articles or materials, not otherwise provided for
- B65B69/0008—Opening and emptying bags
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B43/00—Forming, feeding, opening or setting-up containers or receptacles in association with packaging
- B65B43/12—Feeding flexible bags or carton blanks in flat or collapsed state; Feeding flat bags connected to form a series or chain
- B65B43/14—Feeding individual bags or carton blanks from piles or magazines
- B65B43/16—Feeding individual bags or carton blanks from piles or magazines by grippers
- B65B43/18—Feeding individual bags or carton blanks from piles or magazines by grippers by suction-operated grippers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B43/00—Forming, feeding, opening or setting-up containers or receptacles in association with packaging
- B65B43/26—Opening or distending bags; Opening, erecting, or setting-up boxes, cartons, or carton blanks
- B65B43/30—Opening or distending bags; Opening, erecting, or setting-up boxes, cartons, or carton blanks by grippers engaging opposed walls, e.g. suction-operated
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B43/00—Forming, feeding, opening or setting-up containers or receptacles in association with packaging
- B65B43/42—Feeding or positioning bags, boxes, or cartons in the distended, opened, or set-up state; Feeding preformed rigid containers, e.g. tins, capsules, glass tubes, glasses, to the packaging position; Locating containers or receptacles at the filling position; Supporting containers or receptacles during the filling operation
- B65B43/54—Means for supporting containers or receptacles during the filling operation
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B51/00—Devices for, or methods of, sealing or securing package folds or closures; Devices for gathering or twisting wrappers, or necks of bags
- B65B51/04—Applying separate sealing or securing members, e.g. clips
- B65B51/07—Sewing or stitching
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B61/00—Auxiliary devices, not otherwise provided for, for operating on sheets, blanks, webs, binding material, containers or packages
- B65B61/04—Auxiliary devices, not otherwise provided for, for operating on sheets, blanks, webs, binding material, containers or packages for severing webs, or for separating joined packages
- B65B61/06—Auxiliary devices, not otherwise provided for, for operating on sheets, blanks, webs, binding material, containers or packages for severing webs, or for separating joined packages by cutting
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65B—MACHINES, APPARATUS OR DEVICES FOR, OR METHODS OF, PACKAGING ARTICLES OR MATERIALS; UNPACKING
- B65B61/00—Auxiliary devices, not otherwise provided for, for operating on sheets, blanks, webs, binding material, containers or packages
- B65B61/26—Auxiliary devices, not otherwise provided for, for operating on sheets, blanks, webs, binding material, containers or packages for marking or coding completed packages
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G33/00—Screw or rotary spiral conveyors
- B65G33/24—Details
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G43/00—Control devices, e.g. for safety, warning or fault-correcting
- B65G43/08—Control devices operated by article or material being fed, conveyed or discharged
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G61/00—Use of pick-up or transfer devices or of manipulators for stacking or de-stacking articles not otherwise provided for
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Textile Engineering (AREA)
- Supplying Of Containers To The Packaging Station (AREA)
Abstract
一种颗粒状农药中间体自动输送装置,属于自动化技术领域,结构上由拆袋装置、反应装置、运料装置、烘干机、分筛灌装装置、套袋装置、转向搬运机、开袋展袋装置、包装装置和码垛打包装置组成,生产及包装的机构数量少,结构简单,空间利用率高,可自动化完成颗粒状农药中间体的输送及包装工作,提高了颗粒状农药中间体的生产效率;利用套袋装置,转向搬运机,开袋展袋装置自动化完成颗粒状农药中间体所需三层袋子的套袋工作,使得所需的工人数量大大减少,降低人工劳动力成本。通过各装置之间的协调性,各模块之间联系紧密,可多个模块同时工作,大大提升了生产量,降低了生产的时间成本,使产品生产制造效率不断提高。
An automated conveying device for granular pesticide intermediates, belonging to the field of automation technology, is structurally composed of a bag-unpacking device, a reaction device, a material conveying device, a dryer, a screening and filling device, a bag-packing device, a steering conveyor, a bag-opening and unpacking device, a packaging device, and a palletizing and packing device. It features a small number of production and packaging mechanisms, a simple structure, and high space utilization. It can automatically complete the conveying and packaging of granular pesticide intermediates, improving production efficiency. The bag-packing device, steering conveyor, and bag-opening and unpacking device automatically complete the bagging of the three layers required for granular pesticide intermediates, significantly reducing the number of workers needed and lowering labor costs. Through the coordination between the various devices and the close connection between the modules, multiple modules can work simultaneously, greatly increasing production volume, reducing production time costs, and continuously improving product manufacturing efficiency.
Description
技术领域technical field
本发明属于自动化技术领域,涉及一种颗粒状农药中间体自动输送装置,特别是涉及一种高效率、机械化生产的颗粒状农药中间体自动输送装备。The invention belongs to the field of automation technology, and relates to an automatic conveying device for granular pesticide intermediates, in particular to an automatic conveying device for granular pesticide intermediates with high efficiency and mechanized production.
背景技术Background technique
目前,中国制造业中产品创新能力薄弱,核心技术过分依赖于国外,制造业生产加工效率低,人工成本不断上升等问题较为突出,为了增强国家及企业在制造业的核心竞争力,一个重要的途径就是不断发展我国的装备制造业,实现产品加工生产的自动化智能化,降低人工劳动力成本,使产品生产制造效率不断增强。At present, China's manufacturing industry has weak product innovation capabilities, excessive dependence on foreign core technologies, low production and processing efficiency in the manufacturing industry, and rising labor costs. In order to enhance the core competitiveness of the country and enterprises in the manufacturing industry, an important The way is to continuously develop my country's equipment manufacturing industry, realize the automation and intelligentization of product processing and production, reduce labor costs, and continuously increase the efficiency of product manufacturing.
在颗粒状农药中间体制造过程中,上料、送料和下料等工序均通过人工进行,存在工作效率低,人工成本高等缺点。因此,设计出一种能降低人工劳动力成本和加工生产的机械化的装置用于颗粒状农药中间体制造过程中就显得尤为重要。In the manufacturing process of granular pesticide intermediates, the processes of feeding, feeding and unloading are all carried out manually, which has the disadvantages of low work efficiency and high labor cost. Therefore, it is particularly important to design a mechanized device that can reduce labor costs and process production for the production of granular pesticide intermediates.
发明内容SUMMARY OF THE INVENTION
本发明的目的在于针对传统颗粒状农药中间体制造过程中,上料、送料和下料等工序均通过人工进行,工作效率低、人工成本高等缺点,提出一种颗粒状农药中间体自动输送装置,装置中所涉及的运动机构简单,机构设置科学合理,空间利用率高,可使多个模块同时工作,可实现产品加工生产的机械化,大幅度提升生产率,进一步降低人工劳动力成本。The object of the present invention is to propose an automatic conveying device for granular pesticide intermediates in view of the shortcomings in the traditional manufacturing process of granular pesticide intermediates, such as feeding, feeding and unloading, which are all performed manually, with low work efficiency and high labor costs. The motion mechanism involved in the device is simple, the mechanism setting is scientific and reasonable, and the space utilization rate is high, which can enable multiple modules to work at the same time, realize the mechanization of product processing and production, greatly improve productivity, and further reduce labor costs.
本发明的技术方案是:一种颗粒状农药中间体自动输送装置,包括高台,其特征在于:所述颗粒状农药中间体自动输送装置由拆袋装置、反应装置、运料装置、烘干机、分筛灌装装置、套袋装置、转向搬运机、开袋展袋装置、包装装置和码垛打包装置组成;所述拆袋装置设置在所述高台上,所述运料装置设置在所述拆袋装置的下方,所述反应装置设置在所述运料装置出料口的下方,所述烘干机设置在所述反应装置左侧,所述分筛灌装装置设置在所述烘干机的左侧,所述套袋装置设置在所述转向搬运机的前方,所述开袋展袋装置设置在所述转向搬运机的后方,所述包装装置设置在所述开袋展袋装置的左侧,所述码垛打包装置设置在所述包装装置的后方;The technical scheme of the present invention is: an automatic conveying device for granular pesticide intermediates, comprising a high platform, and is characterized in that: the automatic conveying device for granular pesticide intermediates consists of a bag unpacking device, a reaction device, a material conveying device, and a dryer. , screening and filling device, bagging device, steering conveyor, bag opening and unfolding device, packaging device and stacking and packaging device; Below the bag unpacking device, the reaction device is arranged below the discharge port of the material conveying device, the dryer is arranged on the left side of the reaction device, and the screening and filling device is arranged on the drying device. On the left side of the dryer, the bagging device is arranged in front of the turning conveyor, the bag opening and unfolding device is arranged behind the turning conveyor, and the packaging device is arranged on the bag opening and unfolding On the left side of the device, the stacking and packaging device is arranged behind the packaging device;
所述拆袋装置由运输带、载料平台、切碎锯盘、伸缩杆、机械手、伸缩气缸和拆袋主体框架连接构成;所述运输带设置在所述拆袋主体框架中间的凹槽处,所述载料平台设置在所述运输带的前方,所述切碎锯盘设置在所述载料平台的上方,所述伸缩杆和伸缩气缸设置在所述切碎锯盘的后方,所述机械手安装在载料平台前方,所述机械手上设置伸缩气缸;The bag unpacking device is composed of a conveyor belt, a material loading platform, a shredding saw disc, a telescopic rod, a manipulator, a telescopic cylinder and a bag unpacking main frame; the conveyor belt is arranged at the groove in the middle of the bag unpacking main frame. , the loading platform is arranged in front of the conveyor belt, the shredding saw disc is arranged above the loading platform, and the telescopic rod and the telescopic cylinder are arranged behind the shredding saw disc, so The manipulator is installed in front of the loading platform, and the manipulator is provided with a telescopic cylinder;
所述反应装置由反应主体框架、粉末浓度感应器和可移动式上井盖连接构成,所述粉末浓度感应器设置在所述主体框架外表面的孔洞内,其末端伸入反应装置的内部;The reaction device is formed by connecting a reaction main body frame, a powder concentration sensor and a movable upper manhole cover, the powder concentration sensor is arranged in a hole on the outer surface of the main body frame, and its end extends into the interior of the reaction device;
所述运料装置由接料器、震动器和螺旋运输管道连接构成;所述震动器均匀分布在所述接料器底盘的下方,所述螺旋运输管道与所述接料器下方送料口相连接,所述烘干机设置在所述螺旋输送管道输送口的下方;The conveying device is composed of a feeder, a vibrator and a screw conveying pipe; the vibrator is evenly distributed under the base of the feeder, and the screw conveying pipe is connected to the feeding port under the feeder. connected, the dryer is arranged below the conveying port of the spiral conveying pipeline;
所述分筛灌装装置由工作机架、分筛机、螺旋输送机和灌装机连接构成;所述分筛机设置在所述工作机架的左侧,所述螺旋输送机设置在所述工作机架的内部,所述灌装机安装在工作机架右侧,所述灌装机的进口与所述螺旋输送机的出口正对设置;The screening and filling device is formed by connecting a working frame, a screening machine, a screw conveyor and a filling machine; the screening machine is arranged on the left side of the working frame, and the screw conveyor is arranged at the Inside the working frame, the filling machine is installed on the right side of the working frame, and the inlet of the filling machine is arranged opposite to the outlet of the screw conveyor;
所述套袋装置由套袋机架、第一平面、第二平面、第三平面、第四平面、第五平面、第六平面、第七平面、第八平面、第九平面、送袋气缸、第一机械臂、真空吸盘、取袋吸盘、取袋气缸、抓袋吸盘、抓袋气缸、第二机械臂、第一开袋吸盘、第二开袋吸盘和机械爪连接构成;所述第一平面至第九平面均设置在所述套袋机架上,所述第一平面设置在所述套袋机架前端,所述第二平面设置在所述第一平面的后方,所述第三平面设置在所述第二平面的左侧,所述第四平面设置在所述第三平面的左侧,所述第五平面设置在所述第二平面的后方,所述第六平面设置在所述第五平面的后方,所述第七平面设置在所述第六平面的左侧,所述第八平面设置在所述第七平面的左侧,所述第九平面设置在所述第六平面的后方,所述第一机械臂设置在第一平面的上方,并由送袋气缸驱动,所述真空吸盘设置在所述第一平面后侧的上方,所述取袋吸盘设置在所述第三平面的上方,所述取袋吸盘由取袋气缸驱动,所述抓袋吸盘和第二机械臂设置在所述第五平面的上方,所述抓袋吸盘由抓袋气缸驱动,所述抓袋气缸低于第二机械臂,所述第八平面上方设有可前后移动的真空吸盘,所述第一开袋吸盘设置在所述第二平面前端的上方,所述第二开袋吸盘和机械爪设置在所述第二平面前端的下方,所述第一开袋吸盘、第二开袋吸盘、机械爪均由气缸驱动;The bagging device consists of a bagging frame, a first plane, a second plane, a third plane, a fourth plane, a fifth plane, a sixth plane, a seventh plane, an eighth plane, a ninth plane, and a bag feeding cylinder. , the first robotic arm, the vacuum suction cup, the suction cup for taking the bag, the cylinder for taking the bag, the suction cup for grabbing the bag, the cylinder for grabbing the bag, the second mechanical arm, the first suction cup for opening the bag, the second suction cup for opening the bag and the mechanical claw are connected to form; The first plane to the ninth plane are all arranged on the bagging frame, the first plane is arranged at the front end of the bagging frame, the second plane is arranged behind the first plane, and the first plane is arranged at the front of the bagging frame. The three planes are arranged on the left side of the second plane, the fourth plane is arranged on the left side of the third plane, the fifth plane is arranged behind the second plane, and the sixth plane is arranged Behind the fifth plane, the seventh plane is disposed on the left side of the sixth plane, the eighth plane is disposed on the left side of the seventh plane, and the ninth plane is disposed on the Behind the sixth plane, the first robotic arm is arranged above the first plane and is driven by a bag feeding cylinder, the vacuum suction cup is arranged above the rear side of the first plane, and the bag taking suction cup is arranged on the back of the first plane. Above the third plane, the bag taking suction cup is driven by a bag taking cylinder, the bag grabbing suction cup and the second mechanical arm are arranged above the fifth plane, and the bag grabbing suction cup is driven by the bag grabbing cylinder, The bag grabbing cylinder is lower than the second mechanical arm, a vacuum suction cup that can move back and forth is arranged above the eighth plane, the first bag opening suction cup is arranged above the front end of the second plane, and the second open The bag suction cup and the mechanical claw are arranged below the front end of the second plane, and the first bag opening suction cup, the second bag opening suction cup and the mechanical claw are all driven by an air cylinder;
所述开袋展袋装置由开袋机架、拿袋台、滑动气缸、滑动平台、拿袋气缸、 拿袋吸盘、展袋气缸、展袋吸盘和多功能机械臂连接构成;所述拿袋台设置在所述开袋机架的前面,所述滑动平台设置在所述开袋机架内表面的滑槽上,所述滑动气缸一端固定在所述开袋机架上,另一端与所述滑动平台连接,所述拿袋气缸设置在所述滑动平台的下方,所述拿袋吸盘设置在所述拿袋气缸的活塞杆底部,所述展袋气缸设置在所述开袋机架的内表面,所述多功能机械臂设置在所述开袋机架的左外表面上;The bag opening and unfolding device is composed of a bag opening frame, a bag holding table, a sliding cylinder, a sliding platform, a bag holding cylinder, a bag holding suction cup, a bag unfolding cylinder, a bag unfolding suction cup and a multifunctional mechanical arm; the bag holding The platform is arranged in front of the bag opening frame, the sliding platform is arranged on the chute on the inner surface of the bag opening frame, one end of the sliding cylinder is fixed on the bag opening frame, and the other end is connected to the bag opening frame. The sliding platform is connected, the bag-holding cylinder is arranged below the sliding platform, the bag-holding suction cup is arranged at the bottom of the piston rod of the bag-holding cylinder, and the bag unfolding cylinder is arranged on the bottom of the bag opening frame. The inner surface, the multifunctional mechanical arm is arranged on the left outer surface of the bag opening frame;
所述包装装置由基座、托袋机械手、移动滑轨、皮带输送机、支撑面板、托板、自动缝线机、切边机、自动打码机和推板连接构成;所述基座设置在地面上,所述移动滑轨设置在所述基座的上表面右侧,所述皮带输送机设置在所述基座的上表面左侧,所述托袋机械手连接设置在所述移动滑轨的上表面,两者通过传动装置相连,所述支撑面板由前支撑面板和后支撑面板构成,所述托板连接设置在支撑面板内表面的中部,所述自动缝线机设置在后支撑面板的前表面中上部,所述切边机设置在后支撑面板的前表面,且位于自动缝线机的左侧,所述自动打码机固定设置在基座上;The packaging device is composed of a base, a bag holding manipulator, a moving slide rail, a belt conveyor, a support panel, a support plate, an automatic sewing machine, a trimming machine, an automatic coding machine and a push plate connection; the base is provided with On the ground, the moving slide rail is arranged on the right side of the upper surface of the base, the belt conveyor is arranged on the left side of the upper surface of the base, and the bag holding manipulator is connected and arranged on the moving slide The upper surface of the rail is connected by a transmission device. The support panel is composed of a front support panel and a rear support panel. The support plate is connected and arranged in the middle of the inner surface of the support panel. The middle and upper part of the front surface of the panel, the edge trimmer is arranged on the front surface of the rear support panel, and is located on the left side of the automatic sewing machine, and the automatic coding machine is fixedly arranged on the base;
所述码垛打包装置由送料机、前后推动机构、上下推动机构、振平机、输送机、待码垛台、码垛机械手、机械手运动轨道、运送机构、盖纸片机、码垛机架、捆绑机、运送机构运动轨道、包膜台和包膜机连接构成;所述振平机设置在所述送料机上部靠前位置,所述振平机后方设置推动装置,输送机与待码垛台相连接,横向放置的运送机构与运送机构运动轨道相配合,所述码垛机械手、盖纸片机、捆绑机和包膜机分别沿运送机构运动轨道依次设置。The stacking and packaging device consists of a feeder, a front and rear push mechanism, an upper and lower push mechanism, a leveling machine, a conveyor, a pallet to be stacked, a stacking robot, a robot movement track, a transport mechanism, a cover sheet machine, and a stacking frame. , a binding machine, a moving track of a conveying mechanism, a coating table and a coating machine are connected; the leveling machine is arranged at the upper front of the feeder, and a pushing device is arranged behind the leveling machine. The pallets are connected, and the transversely placed conveying mechanism cooperates with the moving track of the conveying mechanism.
所述机械爪高度与第二平面相同。The height of the gripper is the same as that of the second plane.
所述展袋吸盘包括上下两吸盘,上吸盘开口朝下,下吸盘开口朝上,上吸盘固定设置在所述展袋气缸底部,下吸盘固定设置在开袋机架上,且与上吸盘相对。The opening suction cup of the unfolding bag includes two suction cups, the upper suction cup is opened downward, the opening of the lower suction cup is upward, the upper suction cup is fixedly arranged at the bottom of the bag unfolding cylinder, and the lower suction cup is fixedly arranged on the bag opening frame, and is opposite to the upper suction cup .
所述支撑面板由前支撑面板和后支撑面板构成,分别安装于基座的前后两侧,前后支撑面板上均设有矩形孔洞,推板设置在前支撑面板的矩形孔洞内,自动打码机正对后支撑面板上的矩形孔洞设置。The support panel is composed of a front support panel and a rear support panel, which are respectively installed on the front and rear sides of the base. The front and rear support panels are provided with rectangular holes, and the push plates are arranged in the rectangular holes of the front support panel. Set right against the rectangular hole in the rear support panel.
所述推动装置由前后推动机构和上下推动机构组成。The pushing device is composed of a front and rear pushing mechanism and an up and down pushing mechanism.
本发明的有益效果为:本发明提供的一种颗粒状农药中间体自动输送装置,结构上由拆袋装置、反应装置、运料装置、烘干机、分筛灌装装置、套袋装置、转向搬运机、开袋展袋装置、包装装置和码垛打包装置组成,生产及包装的机构数量少,结构简单,空间利用率高,可自动化完成颗粒状农药中间体自动输送装备的生产及包装工作,提高了颗粒状农药中间体的生产效率;利用套袋装置,转向搬运机,开袋展袋装置自动化完成颗粒状农药中间体所需三层袋子的套袋工作,使得所需的工人数量大大减少,降低人工劳动力成本。通过各装置之间的协调性,各模块之间联系紧密,可多个模块同时工作,大大提升了生产量,降低了生产的时间成本,使产品生产制造效率不断提高。The beneficial effects of the present invention are as follows: an automatic conveying device for granular pesticide intermediates provided by the present invention is structurally composed of a bag unpacking device, a reaction device, a material conveying device, a dryer, a screening and filling device, a bagging device, It is composed of a steering conveyor, a bag opening and unfolding device, a packaging device and a stacking and packaging device. The number of production and packaging mechanisms is small, the structure is simple, and the space utilization rate is high. It can automatically complete the production and packaging of automatic conveying equipment for granular pesticide intermediates. work, improve the production efficiency of granular pesticide intermediates; use the bagging device, turn the conveyor, open the bag and unfold the bag device to automatically complete the bagging work of the three-layer bags required for the granular pesticide intermediates, so that the required number of workers Greatly reduce and reduce labor cost. Through the coordination between the devices, the modules are closely connected, and multiple modules can work at the same time, which greatly improves the production volume, reduces the time cost of production, and continuously improves the production efficiency of products.
附图说明Description of drawings
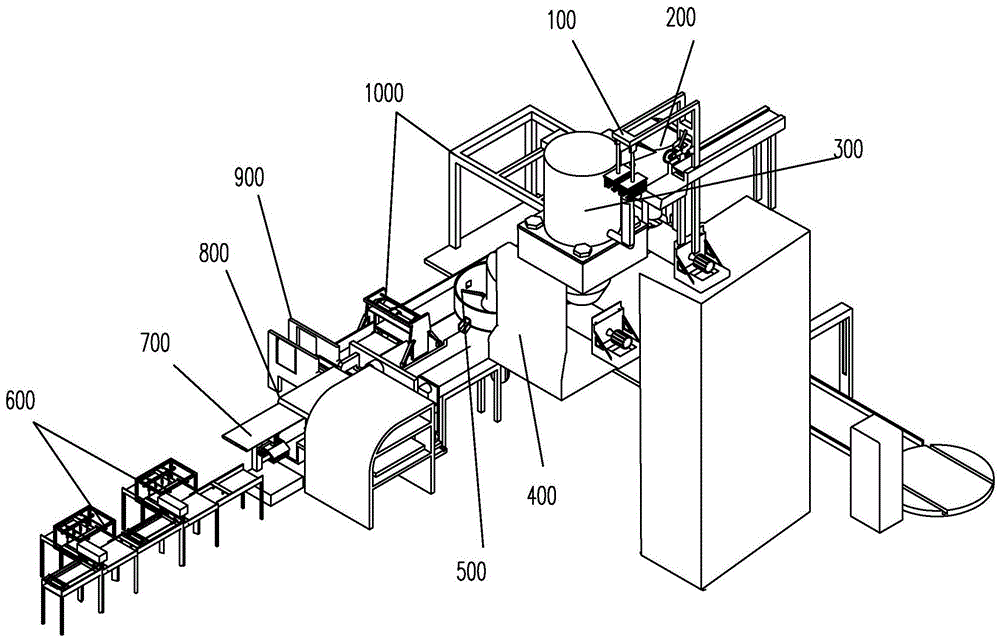
图1 为本发明总体结构示意图。FIG. 1 is a schematic diagram of the overall structure of the present invention.
图2 为本发明局部放大结构示意图。FIG. 2 is a schematic diagram of a partially enlarged structure of the present invention.
图3 为本发明中拆袋装置的立体结构示意图。FIG. 3 is a schematic three-dimensional structure diagram of the bag dismantling device in the present invention.
图4 为本发明中反应装置的立体结构示意图。FIG. 4 is a schematic diagram of the three-dimensional structure of the reaction device in the present invention.
图5 为本发明中运料装置的立体结构示意图。FIG. 5 is a schematic three-dimensional structure diagram of the material conveying device in the present invention.
图6 为本发明中分筛灌装装置的立体结构示意图。FIG. 6 is a schematic three-dimensional structure diagram of the screening and filling device in the present invention.
图7 为本发明中套袋装置的立体结构示意图。FIG. 7 is a schematic three-dimensional structure diagram of the bagging device in the present invention.
图8 为本发明中开袋展袋装置的立体结构示意图。FIG. 8 is a schematic diagram of the three-dimensional structure of the bag opening and unfolding device in the present invention.
图9 为本发明中包装装置的立体结构示意图。FIG. 9 is a schematic three-dimensional structure diagram of the packaging device in the present invention.
图10 为本发明中码垛打包装置的立体结构示意图。FIG. 10 is a schematic three-dimensional structure diagram of the palletizing and packaging device in the present invention.
图中:拆袋装置100、反应装置200、运料装置300、烘干机400、分筛灌装装置500、套袋装置600、转向搬运机700、开袋展袋装置800、包装装置900、码垛打包装置1000、运输带101、载料平台102、切碎锯盘103、伸缩杆104、机械手105、伸缩气缸106、拆袋主体框架107、主体框架201、粉末浓度感应器202、可移动式上井盖203、接料器301、震动器302、螺旋运输管道303、工作机架501、分筛机502、螺旋输送机503、灌装机504、套袋机架601、第一平面602、第二平面603、第三平面604、第四平面605、第五平面606、第六平面607、第七平面608、第八平面609、第九平面610、送袋气缸611、第一机械臂612、真空吸盘613、取袋吸盘614、取袋气缸615、抓袋吸盘616、抓袋气缸617、第二机械臂618、开袋吸盘619、开袋吸盘620、机械爪621、开袋机架801、拿袋台802、滑动气缸803、滑动平台804、拿袋气缸805、拿袋吸盘806、展袋气缸807、展袋吸盘808、多功能机械臂809、基座901、托袋机械手902、移动滑轨903、皮带输送机904、支撑面板905、托板906、自动缝线机907、切边机908、自动打码机909、推板910、送料机1001、前后推动机构1002、上下推动机构1003、振平机1004、输送机1005、待码垛台1006、码垛机械手1007、机械手运动轨道1008、运送机构1009、盖纸片机1010、码垛机架1011、捆绑机1012、运送机构运动轨道1013、包膜台1014、包膜机1015、袋子1101、灌装后产品1102、包装后产品1103。In the figure: bag opening device 100, reaction device 200, material conveying device 300, dryer 400, screening and filling device 500, bagging device 600, turning conveyor 700, bag opening and unfolding device 800, packaging device 900, Palletizing and packaging device 1000, conveyor belt 101, loading platform 102, shredding saw disc 103, telescopic rod 104, manipulator 105, telescopic cylinder 106, bag unpacking main frame 107, main frame 201, powder concentration sensor 202, movable manhole cover 203, feeder 301, vibrator 302, screw conveying pipe 303, working frame 501, screening machine 502, screw conveyor 503, filling machine 504, bagging frame 601, first plane 602, The second plane 603, the third plane 604, the fourth plane 605, the fifth plane 606, the sixth plane 607, the seventh plane 608, the eighth plane 609, the ninth plane 610, the bag feeding cylinder 611, the first robot arm 612 , vacuum suction cup 613, bag taking suction cup 614, bag taking cylinder 615, bag grabbing suction cup 616, bag grabbing cylinder 617, second robotic arm 618, bag opening suction cup 619, bag opening suction cup 620, mechanical claw 621, bag opening rack 801 , bag holding table 802, sliding cylinder 803, sliding platform 804, bag holding cylinder 805, bag holding suction cup 806, bag display cylinder 807, bag display suction cup 808, multi-functional robotic arm 809, base 901, bag holding manipulator 902, mobile Slide rail 903, belt conveyor 904, support panel 905, pallet 906, automatic sewing machine 907, trimming machine 908, automatic coding machine 909, push plate 910, feeder 1001, front and rear push mechanism 1002, up and down push mechanism 1003, leveling machine 1004, conveyor 1005, pallet to be palletized 1006, palletizing manipulator 1007, manipulator movement track 1008, conveying mechanism 1009, cover sheet machine 1010, palletizing rack 1011, binding machine 1012, conveying mechanism movement Track 1013, coating table 1014, coating machine 1015, bag 1101, product after filling 1102, product after packaging 1103.
具体实施方式Detailed ways
下面结合附图对本发明作进一步说明:The present invention will be further described below in conjunction with the accompanying drawings:
如图1-2所示,一种颗粒状农药中间体自动输送装置,颗粒状农药中间体自动输送装置由拆袋装置100、反应装置200、运料装置300、烘干机400、分筛灌装装置500、套袋装置600、转向搬运机700、开袋展袋装置800、包装装置900和码垛打包装置1000组成;拆袋装置100设置在高台上,运料装置300设置在拆袋装置100的下方,反应装置200设置在运料装置300出料口的下方,烘干机400设置在反应装置200左侧,分筛灌装装置500设置在烘干机400的左侧,套袋装置600设置在转向搬运机700的前方,开袋展袋装置800设置在转向搬运机700的后方,包装装置900设置在开袋展袋装置800的左侧,码垛打包装置1000设置在包装装置900的后方。As shown in Figure 1-2, an automatic conveying device for granular pesticide intermediates, the automatic conveying device for granular pesticide intermediates consists of a
如图3所示,一种颗粒状农药中间体自动输送装置,拆袋装置100由运输带101、载料平台102、切碎锯盘103、伸缩杆104、机械手105、伸缩气缸106和拆袋主体框架107连接构成;运输带101设置在拆袋主体框架107中间的凹槽处,载料平台102设置在运输带101的前方,切碎锯盘103设置在载料平台102的上方,伸缩杆104和伸缩气缸106设置在切碎锯盘103的后方,机械手105安装在载料平台102前方,机械手105上设置伸缩气缸106。As shown in Figure 3, an automatic conveying device for granular pesticide intermediates, the
如图4所示,一种颗粒状农药中间体自动输送装置,反应装置200由反应主体框架201、粉末浓度感应器202和可移动式上井盖203连接构成,粉末浓度感应器202设置在主体框架201外表面的孔洞内,其末端伸入反应装置的内部。As shown in FIG. 4, an automatic conveying device for granular pesticide intermediates, the
如图5所示,一种颗粒状农药中间体自动输送装置,运料装置300由接料器301、震动器302和螺旋运输管道303连接构成;震动器302均匀分布在接料器301底盘的下方,螺旋运输管道303与接料器301下方送料口相连接,烘干机400设置在螺旋送料机303输送口的下方。As shown in Fig. 5, an automatic conveying device for granular pesticide intermediates, the conveying
如图6所示,一种颗粒状农药中间体自动输送装置,分筛灌装装置500由工作机架501、分筛机502、螺旋输送机503和灌装机504连接构成;分筛机502设置在工作机架501的左侧,螺旋输送机503设置在工作机架501的内部,灌装机504安装在工作机架501右侧,灌装机504的进口与螺旋输送机503的出口正对设置。As shown in Figure 6, an automatic conveying device for granular pesticide intermediates, the screening and filling
如图7所示,一种颗粒状农药中间体自动输送装置,套袋装置600由套袋机架601、第一平面602、第二平面603、第三平面604、第四平面605、第五平面606、第六平面607、第七平面608、第八平面609、第九平面610、送袋气缸611、第一机械臂612、真空吸盘613、取袋吸盘614、取袋气缸615、抓袋吸盘616、抓袋气缸617、第二机械臂618、第一开袋吸盘619、第二开袋吸盘620和机械爪621连接构成;第一平面602至第九平面610均设置在套袋机架601上,第一平面602设置在套袋机架601前端,第二平面603设置在第一平面602的后方,第三平面604设置在第二平面603的左侧,第四平面605设置在第三平面604的左侧,第五平面606设置在第二平面603的后方,第六平面607设置在第五平面606的后方,第七平面608设置在第六平面607的左侧,第八平面609设置在第七平面608的左侧,第九平面610设置在第六平面607的后方,第一机械臂612设置在第一平面602的上方,并由送袋气缸611驱动,真空吸盘613设置在第一平面602后侧的上方,取袋吸盘614设置在第三平面604的上方,取袋吸盘614由取袋气缸615驱动,抓袋吸盘616和机第二械臂618设置在第五平面606的上方,抓袋吸盘616由抓袋气缸617驱动,抓袋气缸617低于第二机械臂618,第八平面609上方设有可前后移动的真空吸盘,第一开袋吸盘619设置在第二平面603前端的上方,第二开袋吸盘620和机械爪621设置在第二平面603前端的下方,第一开袋吸盘619、第二开袋吸盘620、机械爪621均由气缸驱动。As shown in FIG. 7, an automatic conveying device for granular pesticide intermediates, the
如图8所示,一种颗粒状农药中间体自动输送装置,开袋展袋装置800由开袋机架801、拿袋台802、滑动气缸803、滑动平台804、拿袋气缸805、拿袋吸盘806、展袋气缸807、展袋吸盘808和多功能机械臂809连接构成;拿袋台802设置在开袋机架801的前面,滑动平台804设置在开袋机架801内表面的滑槽上,滑动气缸803一端固定在开袋机架801上,另一端与滑动平台804连接,拿袋气缸805设置在滑动平台804的下方,拿袋吸盘806设置在拿袋气缸805的活塞杆底部,展袋气缸807设置在开袋机架801的内表面,多功能机械臂809设置在开袋机架801的左外表面上,展袋吸盘808包括上下两吸盘,上吸盘开口朝下,上吸盘开口朝上,上吸盘固定设置在开袋气缸805底部,下吸盘固定设置在开袋机架801上,且与上吸盘相对。As shown in Figure 8, an automatic conveying device for granular pesticide intermediates, the bag opening and unfolding
如图9所示,一种颗粒状农药中间体自动输送装置,包装装置900由基座901、托袋机械手902、移动滑轨903、皮带输送机904、支撑面板905、托板906、自动缝线机907、切边机908、自动打码机909和推板910连接构成;基座901设置在地面上,移动滑轨903设置在基座901的上表面右侧,皮带输送机904设置在基座901的上表面左侧,托袋机械手902连接设置在移动滑轨903的上表面,两者通过传动装置相连,支撑面板905由前支撑面板和后支撑面板构成,分别安装于基座901的前后两侧,前后支撑面板上均设有矩形孔洞,推板910设置在前支撑面板的矩形孔洞内,自动打码机909正对后支撑面板上的矩形孔洞设置,托板906连接设置在支撑面板905内表面的中部,自动缝线机907设置在后支撑面板的前表面中上部,切边机908设置在后支撑面板的前表面,且位于自动缝线机907的左侧,自动打码机909固定设置在基座901上。As shown in Figure 9, an automatic conveying device for granular pesticide intermediates, the
如图10所示,一种颗粒状农药中间体自动输送装置,码垛打包装置1000由送料机1001、前后推动机构1002、上下推动机构1003、振平机1004、输送机1005、待码垛台1006、码垛机械手1007、机械手运动轨道1008、运送机构1009、盖纸片机1010、码垛机架1011、捆绑机1012、运送机构运动轨道(1013)、包膜台1014和包膜机1015连接构成;振平机1004设置在送料机1001上部靠前位置,振平机1004后方设置推动装置,推动装置由前后推动机构1002和上下推动机构1003组成,输送机1005与待码垛台1006相连接,横向放置的运送机构1009与运送机构运动轨道1013相配合,码垛机械手1007、盖纸片机1010、捆绑机1012和包膜机1015分别沿运送机构运动轨道1013依次设置。As shown in Figure 10, an automatic conveying device for granular pesticide intermediates, a stacking and
如图1-10所示,一种颗粒状农药中间体自动输送装置的工作原理如下:As shown in Figure 1-10, the working principle of an automatic conveying device for granular pesticide intermediates is as follows:
原料袋首先经由拆袋装置100,通过运输带101将其运到载料平台102,随后机械手105在伸缩气缸106的作用下抓取原料袋,切碎锯盘103在伸缩杆104作用下延伸至原料袋的下方,随后在伸缩气缸106的作用下完成对原料袋的上下切割。之后原料通过运料漏斗进入运料装置300,通过运料装置300输送至反应装置200,反应装置200内有粉末浓度感应器202了解反应进行程度,并可通过打开可移动式上井盖203添加原料,反应产物通过下方运料器301经由震动器302使其进入螺旋运输机303,螺旋运输机303下方有压力传感器感知管道内粉末的量,以此调整运输速率,输送的原料经过烘干机400烘干后由螺旋运输机203运往分筛灌装装置500上分筛机502上方料斗中,在料斗中的中间体粉末会在分筛机的作用下分离并将不合格废料通过分筛机502周围废料口排出,剩余合格产品将会在重力作用下通过分筛机502运料口输送到分筛灌装装置500内部螺旋输送机503中,螺旋输送机503会将产品送往灌装机504处等待灌装。The raw material bag is first transported to the
套袋过程是:三种包装袋分别放置在第一平面602、第四平面605、第八平面609上。第四平面605上的2号包装袋可被取袋吸盘614抓取并放置到第三平面604上,包装袋2被放置到第三平面604上后,由机械爪621抓取到第二平面603上。包装袋2被抓取到第二平面603上后,开袋吸盘619和开袋吸盘620分别吸住2号包装袋的袋口上面和下面,将其打开。1号包装袋底部由真空吸盘613抓取,当1号包装袋上升至一定高度时,机械臂612抓取1号包装袋并且真空吸盘613关闭,机械臂612前端下方的真空吸盘,可将1号包装袋吸住,然后机械臂612将1号包装袋送入被打开的2号包装袋中。当1号包装袋被送入2号包装袋内并且机械臂612撤出后,开袋吸盘619和开袋吸盘620关闭,抓袋吸盘616抓取套好的包装袋至平面606。将套好的1、2号包装袋套入3号包装袋中的过程与上述过程相似,不再重复叙述。The bagging process is as follows: three kinds of packaging bags are placed on the
当套好的袋子积攒到一定数量后会由转向搬运机700抓取,换向并运输到开袋展袋装置800上的拿袋台802上。拿袋气缸805收到信号开始推动活塞杆向下运动直至拿袋吸盘806底部接触到袋面,通过拿袋吸盘806的 吸附特性实现抓取功能,吸附住以后,拿袋气缸805的活塞杆向上运动,从而带动袋子上升到预定高度,滑动平台804在滑动气缸803的作用下带动拿袋气缸805、拿袋吸盘806和袋子一起沿滑槽方向运动至对应位置,到达预定位置后,拿袋吸盘806解除吸力,使袋子落入展袋吸盘808上,下展袋吸盘808开始工作吸住包装袋1的下表面,同时展袋气缸807开始推动动活塞杆向下运动,直至展袋气缸807底部的上展袋吸盘802底部接触到袋面并吸附住袋子的上表面,展袋气缸807的活塞杆带动上展袋吸盘808向上运动到一定高度,从而实现袋口的的张开工作,袋口张开口,多功能机械臂809的爪子立即伸入到袋中,上爪与袋子上表面相接触,下爪与袋子的下表面相接触,待多功能机械臂809撑开并抓牢袋子后,展袋吸盘807立即解除吸力,多功能机械臂809转动90度,带动袋子一起旋转,使展开的袋子袋口朝向灌装机504的灌料口 ,灌装机504上的夹子将袋口边沿固定,并给予灌装机504灌装信号,灌装机504开始工作,进行灌装,当灌装到一定数量后,灌装机停止工作,松开夹子,多功能机械臂809将灌装后的袋装产品一1101放入到托袋机械手902上。When the wrapped bags are accumulated to a certain amount, they will be grabbed by the steering
灌装完的袋装产品一1101落入到托袋机械手902后,托袋机械手902立即握紧袋装产品一1101,并带动袋装产品一1101一起沿着移动滑轨903移动到皮带输送机902前方,托袋机械手902松开,袋装产品一1101在皮带输送机904的作用下开始移动,在经过道路上的自动缝线机907,切边机908,自动打码机909时分别完成缝线,切边,打码等一系列操作,当输送到推板910前方时,推板910在电动机的作用下沿销轴转动完成袋装产品二1102的推倒流程,进入下一步骤。After the filled bagged product 1 1101 falls into the
当袋装产品二1102进入袋装除草剂送料线1001上后,其会随着袋装除草剂送料机1001一起运动,当经过振平机1004时,完成振平工作后,推动装置可以较为快速的将除草剂推向输送机1005,完成之后的工作并且可以收回,不影响之后袋装除草剂送料机1001的运转。输送机1005与袋装除草剂待码垛台1006相连接,当除草剂经过运输到达袋装除草剂待码垛台1006后可以暂时存留下除草剂。当除草剂到达袋装除草剂待码垛台1006后,装在机架上可自由前后移动的码垛机械手1007会沿着机械手运动轨道1008把除草剂提起并运送到它底下的运送机构1009上。当除草剂到达运送机构1009上病达到一定数量后,运送机构将会感应到并沿着运送机构运动轨道1013将除草剂送到盖纸片机1010边,到达盖纸片机械手底下时,盖纸片机械手会给堆放的除草剂盖上纸片,轨道两旁的盖纸片机1010会将盖头压平。当盖纸片机1010完成工作后,运送机构1009将会继续沿着轨道1013前进并经过轨道旁的捆绑机1012,捆绑机将会吐出线并给码好垛的除草剂进行包线捆绑。捆绑机1012完成工作后,运送机构1009将会继续前进并到达处于轨道终点处的包膜台1014,该包膜台将固定住运送机构1009,固定完后,包膜台1014会进行旋转,此时包膜台1014右边的的包膜机1015将会给码好垛的除草剂进行包膜。When the bagged product 2 1102 enters the bagged
Claims (5)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201811403194.4A CN109353627B (en) | 2018-11-23 | 2018-11-23 | Automatic conveyor of granular pesticide midbody |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201811403194.4A CN109353627B (en) | 2018-11-23 | 2018-11-23 | Automatic conveyor of granular pesticide midbody |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN109353627A CN109353627A (en) | 2019-02-19 |
| CN109353627B true CN109353627B (en) | 2020-07-14 |
Family
ID=65338478
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201811403194.4A Active CN109353627B (en) | 2018-11-23 | 2018-11-23 | Automatic conveyor of granular pesticide midbody |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN109353627B (en) |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112690171B (en) * | 2019-10-22 | 2022-08-26 | 庆元县春晓自动化科技有限公司 | Automatic film covering protection bag device for producing mushroom sticks |
| CN110697419B (en) * | 2019-11-13 | 2025-04-22 | 无锡正佳自控系统股份有限公司 | An intelligent material conveying system |
| CN111874580A (en) * | 2020-07-01 | 2020-11-03 | 邱荣奎 | Automatic conveying equipment for granular pesticide intermediates |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4323952A1 (en) * | 1993-07-16 | 1995-01-19 | Gasner Benno | Device for loading a garbage sorting device with the contents of garbage bags |
| CN205381427U (en) * | 2016-03-01 | 2016-07-13 | 江西和圣堂科技发展有限公司 | High -speed pillow package machine |
| CN207312666U (en) * | 2017-09-11 | 2018-05-04 | 上海稳优实业有限公司 | Automatic charging device for composition epoxy resin |
| CN108058862A (en) * | 2017-12-01 | 2018-05-22 | 哈尔滨博实自动化股份有限公司 | A kind of packing method and device suitable for M shape square opening bags |
| CN108327964A (en) * | 2017-12-30 | 2018-07-27 | 芜湖瑞思机器人有限公司 | A kind of bottle automatic stacking system and its application method |
-
2018
- 2018-11-23 CN CN201811403194.4A patent/CN109353627B/en active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4323952A1 (en) * | 1993-07-16 | 1995-01-19 | Gasner Benno | Device for loading a garbage sorting device with the contents of garbage bags |
| CN205381427U (en) * | 2016-03-01 | 2016-07-13 | 江西和圣堂科技发展有限公司 | High -speed pillow package machine |
| CN207312666U (en) * | 2017-09-11 | 2018-05-04 | 上海稳优实业有限公司 | Automatic charging device for composition epoxy resin |
| CN108058862A (en) * | 2017-12-01 | 2018-05-22 | 哈尔滨博实自动化股份有限公司 | A kind of packing method and device suitable for M shape square opening bags |
| CN108327964A (en) * | 2017-12-30 | 2018-07-27 | 芜湖瑞思机器人有限公司 | A kind of bottle automatic stacking system and its application method |
Also Published As
| Publication number | Publication date |
|---|---|
| CN109353627A (en) | 2019-02-19 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN205554756U (en) | Full -automatic box filler | |
| CN105151353B (en) | A kind of fully-automatic intelligent picks up brick packaging system | |
| CN103112608B (en) | Pouch-packaged product-collecting and quantitatively filling system and the package packing machine containing this system | |
| CN204369132U (en) | A kind of multi-function robot palletizing system | |
| CN205525197U (en) | Novel stromatolite packagine machine | |
| CN103085998B (en) | Fully automatic integral package packing machine | |
| CN106005635A (en) | Novel automatic bale opener | |
| CN109625431B (en) | Full-automatic material arranging and packaging equipment for shaft workpieces | |
| CN207129169U (en) | A kind of jumbo bag automatic packaging production line | |
| KR101587832B1 (en) | Packaging device for hardtack | |
| CN107380535A (en) | One kind automation explosive packer | |
| CN108327994A (en) | A multi-bag synchronous bag quantitative filling device | |
| CN107927040B (en) | A method for automatically producing Yuanbao wontons | |
| CN108190101A (en) | A kind of assembling boxing apparatus | |
| JP2541424B2 (en) | Case automatic opening box, article removal, folding device | |
| CN109353627A (en) | An automatic conveying device for granular pesticide intermediates | |
| CN115402578A (en) | Double-layer packaging bag bagging, filling and tying integrated machine and bag bagging, filling and tying method thereof | |
| CN104691803A (en) | Heavy film packaging machine | |
| CN206446856U (en) | A kind of paper wrapper vermicelli sack filling machine | |
| CN204937580U (en) | A kind of blended sliver cigarette automatic packaging machine | |
| CN204623899U (en) | A kind of heavy film wrapping machine | |
| CN113636340A (en) | Automatic packaging line for diamond slices | |
| CN208412289U (en) | A kind of piled bricks paper jam set system | |
| CN103612783B (en) | A kind of multi-functional full specification tobacco leaf full automaticity is packaged into covering device | |
| CN216186243U (en) | A fully automatic secondary packaging device for hot melt adhesive |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant |