CN103213800A - Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof - Google Patents
Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof Download PDFInfo
- Publication number
- CN103213800A CN103213800A CN2013101644675A CN201310164467A CN103213800A CN 103213800 A CN103213800 A CN 103213800A CN 2013101644675 A CN2013101644675 A CN 2013101644675A CN 201310164467 A CN201310164467 A CN 201310164467A CN 103213800 A CN103213800 A CN 103213800A
- Authority
- CN
- China
- Prior art keywords
- receiving platform
- cargo
- platform
- unit
- centralizing
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Landscapes
- Warehouses Or Storage Devices (AREA)
Abstract
本发明公开了一种自动化立体仓库单元货物自动调正入库站台,包括机架,设置在机架上的用以承载单元货物并向前输送的输送机构,还包括设置在输送机构进货端中间且其上设置有重量传感器的接货平台、设置在接货平台两侧的矫正机构以及控制器,所述的接货平台受驱可垂直上下移动,所述的扶正机构包括分别设置在接货平台两侧的左扶正板和右扶正板,所述的左扶正板和右扶正板可受驱同步反向移动。同时还公开了其调整方法采用上举式接货平台,接货位置抬高,摆脱了两侧横向挡板限制,叉车交货时仅需大概对齐放置即可,然后在接货平台下降的过程中驱动扶正机构动作完成居中对齐,省时省力省工,降低成本和用工要求。
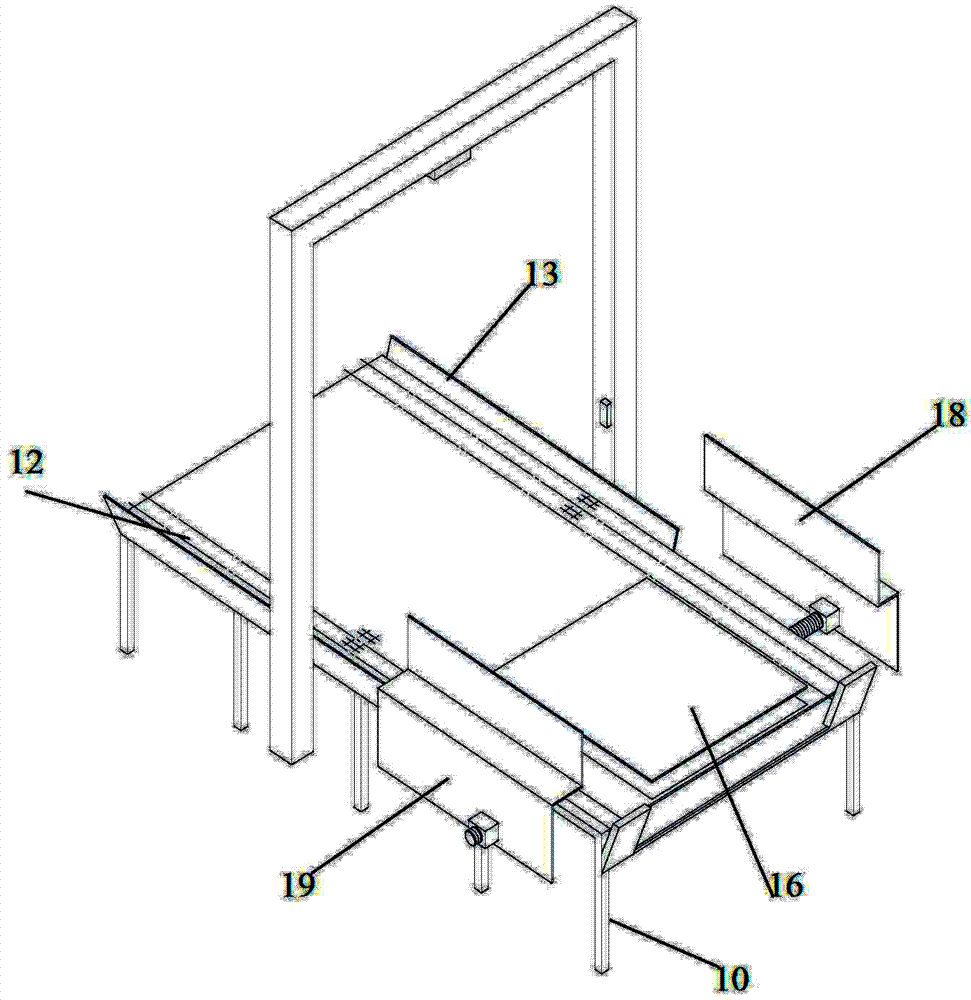
The invention discloses an automatic three-dimensional warehouse unit cargo automatic adjustment storage platform, which includes a frame, a conveying mechanism arranged on the frame to carry the unit cargo and convey it forward, and a delivery mechanism arranged in the middle of the delivery end of the conveying mechanism And there is a receiving platform with a weight sensor, a correction mechanism and a controller arranged on both sides of the receiving platform, the receiving platform is driven to move vertically up and down, and the supporting mechanism includes The left centralizing board and the right centralizing board on both sides of the platform, the left centralizing board and the right centralizing board can be driven to move synchronously in reverse. At the same time, it also discloses that the adjustment method adopts the lift-type receiving platform, and the receiving position is raised, which gets rid of the restrictions of the lateral baffles on both sides. When the forklift is delivered, it only needs to be roughly aligned and placed, and then the receiving platform is lowered. The action of the middle-drive centralizing mechanism is centered and aligned, which saves time, labor and labor, and reduces costs and labor requirements.
Description
技术领域technical field
本发明涉及机械的贮存装置技术领域,特别是涉及一种自动化立体仓库单元货物自动调正入库站台及其货物调正方法。The invention relates to the technical field of mechanical storage devices, in particular to an automatic three-dimensional warehouse unit cargo automatic adjustment storage platform and a cargo adjustment method.
背景技术Background technique
自动化立体仓库,也叫自动化立体仓储,其利用立体仓库设备可实现仓库高层合理化,存取自动化,操作简便化:自动化立体仓库,是当前技术水平较高的形式。自动化立体仓库的主体由货架,巷道式堆垛起重机、入(出)库工作台和自动运进(出)及操作控制系统组成。货架是钢结构或钢筋混凝土结构的建筑物或结构体,货架内是标准尺寸的货位空间,巷道堆垛起重机穿行于货架之间的巷道中,完成存、取货的工作。Automated three-dimensional warehouse, also known as automated three-dimensional warehouse, uses three-dimensional warehouse equipment to realize high-level rationalization of warehouses, automatic access, and simplified operation: automated three-dimensional warehouse is a form with a relatively high level of technology. The main body of the automated three-dimensional warehouse is composed of shelves, roadway stacking cranes, entry (exit) warehouse workbench and automatic entry (exit) and operation control system. The shelf is a building or structure with a steel structure or reinforced concrete structure. The shelf is a standard-sized cargo space. The roadway stacking crane walks through the roadway between the shelves to complete the work of depositing and picking up goods.
辊道式或链式输送机式入库站台是自动化立体仓库库前输送系统的主要设备之一,位于库前输送系统前端,是单元货物的转载平台,对外与叉车实现单元货物对接,对内和输送小车相连,单元货物入库时,通常是使用叉车将组好盘的单元货物放到入库站台上,经尺寸、重量检测合格后,转载至输送小车进行自动入库。The roller-type or chain conveyor-type storage platform is one of the main equipments of the front-end conveying system of the automated three-dimensional warehouse. It is located at the front end of the conveying system in front of the warehouse. Connected with the conveying trolley, when the unit goods are put into the warehouse, the assembled unit goods are usually placed on the storage platform by using a forklift. After passing the size and weight inspection, they are transferred to the conveying trolley for automatic storage.
图1所示为现有技术的链式输送机入库站台的结构示意图。如图1所示,现有的链式输送机式入库站台包括机架1、设置在机架1两侧的单元货物输送链条2、设置在单元货物输送链条外侧的横向固定挡板3以及横向设置在机架进料端的固定挡块4和测量单元货物宽度与高度的龙门式检测架5,所述的检测架上设置有高度传感器和宽度传感器等。FIG. 1 is a schematic structural diagram of a storage platform of a chain conveyor in the prior art. As shown in Figure 1, the existing chain conveyor type storage platform includes a frame 1, a unit cargo conveying chain 2 arranged on both sides of the frame 1, a horizontal fixed
但是现有的自动化立体仓库入库站台的作业面,即两横向固定挡板间的间距与托盘等宽,在实际入库操作时,通常是一人观察,一人操作叉车,往往需要反复调整车位才能对正入库口,影响了入库效率,而且过多依赖工人技术水平,大大增加了人工成本。However, the working surface of the storage platform of the existing automated three-dimensional warehouse, that is, the distance between the two horizontal fixed baffles is equal to the width of the pallet. During the actual storage operation, one person usually observes and one person operates the forklift, and it is often necessary to repeatedly adjust the parking space. Aligning the warehousing entrance affects the efficiency of warehousing, and relies too much on the technical level of workers, which greatly increases labor costs.
发明内容Contents of the invention
本发明的目的是针对现有技术中存在的技术缺陷,而提供一种叉车与其交接简单,降低人工成本的自动化立体仓库单元货物自动调正入库站台及其调正方法。The object of the present invention is to aim at the technical defects existing in the prior art, and provide a kind of forklift truck and its handover is simple, and the automatic three-dimensional warehouse unit cargo automatic adjustment warehouse-in platform and its adjustment method can reduce labor cost.
为实现本发明的目的所采用的技术方案是:The technical scheme adopted for realizing the purpose of the present invention is:
一种自动化立体仓库单元货物自动调正入库站台,包括机架,设置在机架上的用以承载单元货物并向前输送的输送机构,还包括设置在输送机构进货端中间且其上设置有重量传感器的接货平台、设置在接货平台两侧的矫正机构以及控制器,所述的控制器与接货平台的重量传感器保持信号连接,同时所述的控制器与接货平台和扶正机构控制连接,所述的接货平台受驱可垂直上下移动,所述的扶正机构包括分别设置在接货平台两侧的左扶正板和右扶正板,所述的左扶正板和右扶正板可受驱同步反向移动。An automatic three-dimensional warehouse unit cargo automatic adjustment storage platform, including a frame, a conveying mechanism arranged on the frame to carry the unit cargo and convey it forward, and also includes a conveyor mechanism arranged in the middle of the incoming end of the conveying mechanism and set on it. There is a receiving platform with a weight sensor, a correction mechanism and a controller arranged on both sides of the receiving platform, and the controller maintains a signal connection with the weight sensor of the receiving platform, and at the same time, the controller is connected with the receiving platform and the righting Mechanism control connection, the described goods receiving platform is driven to move vertically up and down, the described righting mechanism includes a left centralizing plate and a right centralizing plate respectively arranged on both sides of the goods receiving platform, and the left centralizing plate and the right centralizing plate Can be driven to move in opposite directions synchronously.
所述的接货平台的驱动可由气缸、油缸或丝杠螺母等驱动,同时所述的左右扶正板也可由气缸、电机等直接控制。The drive of the receiving platform can be driven by cylinders, oil cylinders or screw nuts, etc., and the left and right righting plates can also be directly controlled by cylinders, motors, etc.
所述的输送机构为链条式,所述的接货平台设置在两链条中间。The conveying mechanism is a chain type, and the receiving platform is arranged in the middle of the two chains.
所述的输送机构为辊道式,所述的接货平台设置在进货端两相邻辊之间。The conveying mechanism is a roller table type, and the receiving platform is arranged between two adjacent rollers at the receiving end.
所述的接货平台的驱动机构包括驱动电机、与所述的驱动电机传动连接的涡轮蜗杆机构和可带动所述的接货平台垂直上下移动的螺旋传动机构。The driving mechanism of the cargo receiving platform includes a driving motor, a worm gear mechanism connected with the driving motor, and a screw transmission mechanism that can drive the cargo receiving platform to move vertically up and down.
所述的左扶正板和右扶正板的驱动机构包括分别于所述的左扶正板和右扶正板螺接的左右旋丝杠,所述的左右旋丝杠与所述的驱动电机可传动连接。The driving mechanism of the left centralizing plate and the right centralizing plate includes left and right screw screws screwed to the left central plate and the right central plate respectively, and the left and right screw is connected in a transmission manner to the driving motor .
在所述的机架两侧、矫正机构的前方设置有横向挡板。Transverse baffles are arranged on both sides of the frame and in front of the correction mechanism.
一种自动化立体仓库单元货物自动调正入库站台的调正方法,包括以下步骤:The invention relates to an adjustment method for automatic adjustment of storage-in platform for unit goods of an automated three-dimensional warehouse, comprising the following steps:
1)在进货前将接货平台升至最高位置,扶正板间距最大;1) Raise the receiving platform to the highest position before the purchase, and the distance between the centralizing plates is the largest;
2)将单元货物放置在接货平台上,重量传感器感测到单元货物存在发出信号给控制器,控制器控制接货平台下降,同时控制左、右扶正板向中间同步移动;2) Place the unit cargo on the cargo receiving platform, the weight sensor senses the presence of the unit cargo and sends a signal to the controller, the controller controls the cargo receiving platform to descend, and at the same time controls the left and right centralizers to move synchronously to the middle;
3)接货平台沉入输送机构下方并将单元货物转交输送机构承载,同时左、右扶正板夹紧单元货物底盘两侧完成对中调正;3) The receiving platform sinks under the conveying mechanism and transfers the unit goods to the conveying mechanism for carrying, and at the same time, the left and right centralizing plates clamp the two sides of the unit cargo chassis to complete the centering adjustment;
4)启动输送机构将单元货物向前输送;4) Start the conveying mechanism to convey the unit goods forward;
5)当单元货物完全离开接货平台上方后,控制器控制接货平台和扶正机构回复到第1步所述的位置。5) When the unit goods completely leave the top of the receiving platform, the controller controls the receiving platform and the righting mechanism to return to the position described in step 1.
与现有技术相比,本发明的有益效果是:Compared with prior art, the beneficial effect of the present invention is:
采用上举式接货平台,接货位置抬高,摆脱了两侧横向挡板限制,叉车交货时仅需大概对齐放置即可,然后在接货平台下降的过程中驱动扶正机构动作完成居中对齐,利用控制器可实现自动化控制,自动检测接货状态并控制对中,通过增加入库站台的自动调正功能,实现叉车与入库站台间的一次性单元货物移栽,简化了入库站台的交货步骤,解决两者之间单元货物转载难的问题,提高入库效率和自动化水平,省时省力省工,降低成本和用工要求。The lift-up receiving platform is adopted, the receiving position is raised, and the restriction of the lateral baffles on both sides is freed. When the forklift is delivered, it only needs to be roughly aligned and placed, and then the centering mechanism is driven to complete the centering during the lowering of the receiving platform. Alignment, using the controller to realize automatic control, automatically detect the receiving status and control the alignment, by adding the automatic adjustment function of the storage platform, the one-time unit cargo transplantation between the forklift and the storage platform is realized, which simplifies the storage The delivery steps of the platform solve the problem of difficult reloading of unit goods between the two, improve storage efficiency and automation level, save time, labor and labor, and reduce costs and labor requirements.
作为优选方案,利用一个驱动电机实现交货平台和扶正机构同步动作,减少控制电器件使用,简化控制步骤,完全机械式传动,提高稳定性和可靠性,降低环境对其影响,成本较低,广泛应用于各种环境。As a preferred solution, use a drive motor to realize the synchronous action of the delivery platform and the righting mechanism, reduce the use of control electrical components, simplify the control steps, complete mechanical transmission, improve stability and reliability, reduce the impact of the environment on it, and the cost is low. Widely used in various environments.
同时上述的控制方法控制简单,完全自动化,有效提高对中准确性,降低人工要求,提高传送速度。At the same time, the above-mentioned control method is simple in control and fully automatic, which can effectively improve the alignment accuracy, reduce labor requirements, and increase the transmission speed.
附图说明Description of drawings
图1所示为现有技术的链式输送机入库站台的结构示意图;Fig. 1 shows the structural representation of the storage platform of the chain conveyor of the prior art;
图2所示为本发明的链式输送机入库站台的结构示意图;Fig. 2 shows the structural representation of chain conveyor storage platform of the present invention;
图3所示为图2所示的原理示意图。FIG. 3 is a schematic diagram of the principle shown in FIG. 2 .
具体实施方式Detailed ways
以下结合附图和具体实施例对本发明作进一步详细说明。应当理解,此处所描述的具体实施例仅仅用以解释本发明,并不用于限定本发明。The present invention will be described in further detail below in conjunction with the accompanying drawings and specific embodiments. It should be understood that the specific embodiments described here are only used to explain the present invention, not to limit the present invention.
如图2和图3所示,本发明的自动化立体仓库单元货物自动调正入库站台,包括机架10,设置在机架上的用以承载单元货物并向前输送的链条12,还包括设置在两链条进货端中间的接货平台16以及设置在接货平台16两侧的矫正机构,所述的接货平台上设置重量传感器17并可按重量传感器信号变化受驱垂直上下移动,所述的扶正机构包括分别设置在接货平台两侧的左扶正板19和右扶正板18,所述的左扶正板和右扶正板可受驱同步反向移动,所述的入库站台还包括控制器,控制器与接货平台的重量传感器保持信号连接,同时控制器与接货平台和扶正机构控制连接。在所述的机架两侧、矫正机构的前方设置有横向挡板13,在完成对正操作后横向挡板13将单元货物限位,防止其在传送过程中发生偏移。As shown in Fig. 2 and Fig. 3, the automatic three-dimensional warehouse unit cargo of the present invention automatically adjusts the storage platform, including a
其中,所述的接货平台的驱动机构包括驱动电机21、与所述的驱动电机传动连接的涡轮蜗杆机构和可带动所述的接货平台垂直上下移动的螺旋传动机构。所述的左扶正板和右扶正板的驱动机构包括分别于所述的左扶正板和右扶正板螺接的左右旋丝杠,所述的左右旋丝杠与所述的驱动电机可传动连接。Wherein, the driving mechanism of the receiving platform includes a
具体地说,所述的蜗轮蜗杆机构的蜗杆22与所述的驱动电机21输出轴连接,同时在所述的蜗杆22末端设置有传动齿轮23,所述的涡轮蜗杆机构的涡轮24的轴将运动传给螺旋传动机构25,螺旋传动机构25即带动接货平台上下竖直移动。蜗轮蜗杆机构具有两个作用:一是自锁作用,可保证载有单元货物的托盘30放到接货平台16上时,不会因为单元货物的自重使接货平台下降;二是减速作用,蜗杆22的较高转速经蜗轮24减速后,可保证接货平台平稳升降。Specifically, the
所述的左右旋丝杠29为两端分别设置有左旋和右旋螺纹的丝杠,同时在左右扶正板上设置有与之匹配的螺母。同时在所述的左、右旋丝杠一端设置有与传动齿轮23啮合的第二传动齿轮26。借助两齿轮的啮合传动可实现驱动电机同时带动接货平台和左、右扶正板动作,当接货平台到达最低位置时,左、右扶正板相互距离最近,从而保证托盘放到链条上时位置对正。The left-
上述自动化立体仓库单元货物自动调正入库站台的调正方法,包括以下步骤:The adjustment method for the automatic adjustment of the storage platform of the above-mentioned automatic three-dimensional warehouse unit goods includes the following steps:
1)在进货前将接货平台升至最高位置,左、右扶正板间距最大;1) Raise the receiving platform to the highest position before the purchase, and the distance between the left and right centralizing plates is the largest;
2)将单元货物放置在接货平台上,重量传感器感测到单元货物存在发出信号给控制器,控制器控制接货平台下降,同时控制两侧的左右扶正板向中间同步移动;2) Place the unit cargo on the cargo receiving platform, the weight sensor senses the existence of the unit cargo and sends a signal to the controller, the controller controls the cargo receiving platform to descend, and at the same time controls the left and right righting plates on both sides to move synchronously to the middle;
3)接货平台沉入输送机构下方并将单元货物转交输送机构承载,同时两侧扶正板夹紧单元货物底盘两侧完成对中调正;3) The receiving platform sinks under the conveying mechanism and transfers the unit goods to the conveying mechanism for carrying, and at the same time, the centralizing plates on both sides clamp the two sides of the unit cargo chassis to complete the centering adjustment;
4)启动输送机构将单元货物向前输送;4) Start the conveying mechanism to convey the unit goods forward;
5)当单元货物完全离开接货平台上方后接货平台和扶正板回复到第一步所述的位置。5) When the unit cargo completely leaves the top of the receiving platform, the receiving platform and the centralizing plate return to the position described in the first step.
上述控制均由控制器实现,控制器与接货平台的重量传感器保持信号连接,同时控制器与接货平台和扶正机构控制连接,借助控制器可实现全部自动化进行,提高智能性,降低人工参与,减少人工成本。The above controls are all realized by the controller, which maintains a signal connection with the weight sensor of the receiving platform, and at the same time, the controller is connected with the receiving platform and the righting mechanism. With the help of the controller, all automation can be realized, improving intelligence and reducing manual participation , Reduce labor costs.
以上所述仅是本发明的优选实施方式,应当指出的是,对于本技术领域的普通技术人员来说,在不脱离本发明原理的前提下,还可以做出若干改进和润饰,这些改进和润饰也应视为本发明的保护范围。The above is only a preferred embodiment of the present invention, it should be pointed out that, for those of ordinary skill in the art, without departing from the principle of the present invention, some improvements and modifications can also be made, these improvements and Retouching should also be regarded as the protection scope of the present invention.
Claims (7)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310164467.5A CN103213800B (en) | 2013-05-07 | 2013-05-07 | Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310164467.5A CN103213800B (en) | 2013-05-07 | 2013-05-07 | Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN103213800A true CN103213800A (en) | 2013-07-24 |
| CN103213800B CN103213800B (en) | 2015-04-01 |
Family
ID=48812047
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201310164467.5A Expired - Fee Related CN103213800B (en) | 2013-05-07 | 2013-05-07 | Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN103213800B (en) |
Cited By (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106256693A (en) * | 2015-06-19 | 2016-12-28 | 金东纸业(江苏)股份有限公司 | Sandwich grade moves apparatus for correcting |
| CN108229871A (en) * | 2016-12-21 | 2018-06-29 | 比亚迪股份有限公司 | Warehoused cargo management-control method and system |
| CN111792250A (en) * | 2019-04-05 | 2020-10-20 | 雷蒙德股份有限公司 | Conveyor cart alignment system and method |
| CN112793982A (en) * | 2021-03-25 | 2021-05-14 | 罗伯泰克自动化科技(苏州)有限公司 | Stacker goods taking and placing system and application method thereof |
| CN113371377A (en) * | 2021-06-16 | 2021-09-10 | 中船重工海为郑州高科技有限公司 | Intelligent cargo carrying platform |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN2688659Y (en) * | 2004-04-23 | 2005-03-30 | 河南省炜隆实业有限公司 | Automatic exhibiting goods apparatus for smokebox |
| CN2792216Y (en) * | 2005-05-19 | 2006-07-05 | 云南昆船设计研究院 | Automatic storage and conveying equipment for cigarette rod-shaped materials |
| EP2128047A1 (en) * | 2008-05-27 | 2009-12-02 | TGW Mechanics GmbH | Holder device for a transport vehicle |
| CN102085957A (en) * | 2011-02-09 | 2011-06-08 | 广运机电(苏州)有限公司 | Automatic three-dimensional warehousing system |
| CN202138843U (en) * | 2011-07-04 | 2012-02-08 | 湖州德能物流设备有限公司 | On-line automatic shaping machine for palletized goods |
| CN202864187U (en) * | 2012-09-20 | 2013-04-10 | 上海精星仓储设备工程有限公司 | Tray code division device used for roboticized stereoscopic warehouse |
| CN203319097U (en) * | 2013-05-07 | 2013-12-04 | 中国人民解放军军事交通学院 | Automatic unit goods alignment warehousing platform of automatic three-dimensional warehouse |
-
2013
- 2013-05-07 CN CN201310164467.5A patent/CN103213800B/en not_active Expired - Fee Related
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN2688659Y (en) * | 2004-04-23 | 2005-03-30 | 河南省炜隆实业有限公司 | Automatic exhibiting goods apparatus for smokebox |
| CN2792216Y (en) * | 2005-05-19 | 2006-07-05 | 云南昆船设计研究院 | Automatic storage and conveying equipment for cigarette rod-shaped materials |
| EP2128047A1 (en) * | 2008-05-27 | 2009-12-02 | TGW Mechanics GmbH | Holder device for a transport vehicle |
| CN102085957A (en) * | 2011-02-09 | 2011-06-08 | 广运机电(苏州)有限公司 | Automatic three-dimensional warehousing system |
| CN202138843U (en) * | 2011-07-04 | 2012-02-08 | 湖州德能物流设备有限公司 | On-line automatic shaping machine for palletized goods |
| CN202864187U (en) * | 2012-09-20 | 2013-04-10 | 上海精星仓储设备工程有限公司 | Tray code division device used for roboticized stereoscopic warehouse |
| CN203319097U (en) * | 2013-05-07 | 2013-12-04 | 中国人民解放军军事交通学院 | Automatic unit goods alignment warehousing platform of automatic three-dimensional warehouse |
Cited By (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN106256693A (en) * | 2015-06-19 | 2016-12-28 | 金东纸业(江苏)股份有限公司 | Sandwich grade moves apparatus for correcting |
| CN106256693B (en) * | 2015-06-19 | 2019-03-05 | 金东纸业(江苏)股份有限公司 | Sandwich grade moves apparatus for correcting |
| CN108229871A (en) * | 2016-12-21 | 2018-06-29 | 比亚迪股份有限公司 | Warehoused cargo management-control method and system |
| CN111792250A (en) * | 2019-04-05 | 2020-10-20 | 雷蒙德股份有限公司 | Conveyor cart alignment system and method |
| CN111792250B (en) * | 2019-04-05 | 2023-07-07 | 雷蒙德股份有限公司 | Conveyor cart alignment system and method |
| US11807459B2 (en) | 2019-04-05 | 2023-11-07 | The Raymond Corporation | Conveyor cart alignment systems and methods |
| CN112793982A (en) * | 2021-03-25 | 2021-05-14 | 罗伯泰克自动化科技(苏州)有限公司 | Stacker goods taking and placing system and application method thereof |
| CN113371377A (en) * | 2021-06-16 | 2021-09-10 | 中船重工海为郑州高科技有限公司 | Intelligent cargo carrying platform |
Also Published As
| Publication number | Publication date |
|---|---|
| CN103213800B (en) | 2015-04-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN106586357B (en) | A logistics palletizer | |
| CN202924393U (en) | Automatic tray conveyer | |
| CN106966176B (en) | Plate feeding machine | |
| CN103213800B (en) | Automatic stereoscopic warehouse unit cargo self-aligning storage platform and alignment method thereof | |
| CN205906736U (en) | Automatic get thing pile up neatly device | |
| CN205471479U (en) | Carry turning device of platform | |
| CN103057943A (en) | Transverse hoist | |
| CN103213849A (en) | Automatic stacking device of concrete blocks and stacking process thereof | |
| CN220466736U (en) | Pallet transfer units and battery processing equipment | |
| CN115649721A (en) | An intelligent storage and handling device | |
| CN203439723U (en) | Full-automatic carton stacker crane | |
| CN203998141U (en) | Pallet stacking de-stacking device | |
| CN203006446U (en) | Rotary ascending and descending roller path | |
| CN106915625A (en) | One kind removes brick machine automatically | |
| CN104444008A (en) | High-density forward-movement storage goods shelf | |
| CN209064816U (en) | Floor truck and carrying mechanism | |
| CN204624708U (en) | A kind of stacker | |
| CN209777569U (en) | A new energy storage vanadium battery stack production and transportation device | |
| CN203319097U (en) | Automatic unit goods alignment warehousing platform of automatic three-dimensional warehouse | |
| CN105129437B (en) | A kind of intensive device for loading tire of container | |
| CN105128909B (en) | A kind of flat automatic kiln car | |
| CN204490023U (en) | A kind of axletree automatic stacking line | |
| CN220033243U (en) | Panel feeding system and panel unloading production line | |
| CN111846835A (en) | Hand-push type conveying elevator | |
| CN111645184A (en) | PC component modularization production line |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20150401 Termination date: 20210507 |