CN107352207B - Logistics code-fetching system suitable for freight container - Google Patents
Logistics code-fetching system suitable for freight container Download PDFInfo
- Publication number
- CN107352207B CN107352207B CN201710680948.XA CN201710680948A CN107352207B CN 107352207 B CN107352207 B CN 107352207B CN 201710680948 A CN201710680948 A CN 201710680948A CN 107352207 B CN107352207 B CN 107352207B
- Authority
- CN
- China
- Prior art keywords
- fork
- loading
- support
- forklift
- conveyor
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G1/00—Storing articles, individually or in orderly arrangement, in warehouses or magazines
- B65G1/02—Storage devices
- B65G1/04—Storage devices mechanical
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65G—TRANSPORT OR STORAGE DEVICES, e.g. CONVEYORS FOR LOADING OR TIPPING, SHOP CONVEYOR SYSTEMS OR PNEUMATIC TUBE CONVEYORS
- B65G61/00—Use of pick-up or transfer devices or of manipulators for stacking or de-stacking articles not otherwise provided for
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/0755—Position control; Position detectors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/08—Masts; Guides; Chains
- B66F9/082—Masts; Guides; Chains inclinable
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/08—Masts; Guides; Chains
- B66F9/085—Multiple forks, i.e. more than one pair mounted on a single mast or with more than one mast
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/12—Platforms; Forks; Other load supporting or gripping members
- B66F9/14—Platforms; Forks; Other load supporting or gripping members laterally movable, e.g. swingable, for slewing or transverse movements
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/20—Means for actuating or controlling masts, platforms, or forks
- B66F9/22—Hydraulic devices or systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F9/00—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes
- B66F9/06—Devices for lifting or lowering bulky or heavy goods for loading or unloading purposes movable, with their loads, on wheels or the like, e.g. fork-lift trucks
- B66F9/075—Constructional features or details
- B66F9/20—Means for actuating or controlling masts, platforms, or forks
- B66F9/24—Electrical devices or systems
Landscapes
- Engineering & Computer Science (AREA)
- Transportation (AREA)
- Structural Engineering (AREA)
- Mechanical Engineering (AREA)
- Civil Engineering (AREA)
- Life Sciences & Earth Sciences (AREA)
- Geology (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Warehouses Or Storage Devices (AREA)
Abstract
本发明公开了一种适用于货运集装箱的物流取码系统,包括装卸平台、装卸装置、分拣装置和电控装置;装卸平台上在前后方向上设有平行设置的纵向导轨;装卸装置包括支撑底架、带式输送机和叉装机,支撑底架的底部设有行走部,带式输送机包括底架输送机电控机构;叉装机包括叉装机电控机构;分拣装置包括设置在装卸装置左右两侧的多个分拣机械臂和机械臂电控机构;电控装置包括工业控制计算机、支撑底架控制回路、带式输送机控制回路、叉装机控制回路、分拣码放控制回路。本适用于货运集装箱的物流取码系统自动化程度较高,能够实现智能操作、提高装卸效率,特别适用于物流仓储的集装运输中针对货运集装箱的装卸货物码放操作。
The invention discloses a logistics code fetching system suitable for freight containers, comprising a loading and unloading platform, a loading and unloading device, a sorting device and an electric control device; the loading and unloading platform is provided with longitudinal guide rails arranged in parallel in the front and rear directions; the loading and unloading device includes a support Underframe, belt conveyor and forklift, the bottom of the supporting underframe is equipped with a walking part, the belt conveyor includes the electric control mechanism of the underframe conveyor; the forklift includes the electric control mechanism of the forklift; the sorting device includes There are multiple sorting manipulators on the left and right sides of the device and the electric control mechanism of the manipulator; the electric control device includes an industrial control computer, a support chassis control circuit, a belt conveyor control circuit, a forklift machine control circuit, and a sorting and stacking control circuit. The logistics code fetching system applicable to freight containers has a high degree of automation, can realize intelligent operation, and improve loading and unloading efficiency, and is especially suitable for loading and unloading cargo stacking operations for freight containers in containerized transportation of logistics warehousing.
Description
技术领域technical field
本发明涉及一种物流取码系统,具体是一种适用于货运集装箱的物流取码系统,属于智能物流技术装备领域。The invention relates to a logistics code retrieval system, in particular to a logistics code retrieval system suitable for freight containers, and belongs to the field of intelligent logistics technology and equipment.
背景技术Background technique
智能物流就是利用条形码、射频识别技术、传感器、全球定位系统等先进的物联网技术通过信息处理和网络通信技术平台广泛应用于物流业运输、仓储、配送、包装、装卸等基本活动环节,实现货物运输过程的自动化运作和高效率优化管理,提高物流行业的服务水平,降低成本,减少自然资源和社会资源消耗,智能物流的发展将会促进区域经济的发展和世界资源优化配置、实现社会化。Intelligent logistics is the use of advanced Internet of Things technologies such as barcodes, radio frequency identification technology, sensors, and global positioning systems. Through information processing and network communication technology platforms, it is widely used in basic activities such as transportation, warehousing, distribution, packaging, and loading and unloading in the logistics industry. The automated operation and efficient optimized management of the transportation process can improve the service level of the logistics industry, reduce costs, and reduce the consumption of natural and social resources. The development of intelligent logistics will promote the development of regional economy and optimize the allocation of world resources to achieve socialization.
物流仓储是现代智能物流中的关键环节,在连接、中转、存放、保管等环节发挥着重要作用,而仓储管理同时也是在物流仓储中占据着核心的地位,精准仓库过程一般包括收货、上架、捡货、补货、发货、盘点几个流程,为实现智能配送,现有技术中出现自动导引运输车,即装备有电磁或光学等自动导引装置,具有安全保护以及各种移载功能的运输车,物流仓储应用中不需驾驶员,以可充电电池为其动力来源,一般可通过电脑来控制其行进路线以及行为、或利用电磁轨道来设立其行进路线以实现仓储货物的调运,但是针对补货或发货进出仓库进行集装运输过程中的装卸货物码放操作依然大量采用人工操作,即操作人员驾驶叉车进行装卸,特别是针对集装箱货物运输,虽然目前为便于运输通常按运输目的地的不同先将各类小型包装的货物集装在便于运输摆放的中型运输箱内后再进行货运集装箱的装箱,但如何合理布局使集装箱的空间利用率最大、如何合理配载布局使集装箱便于多目的地运输等集装箱问题和卸载过程中的分拣问题致使集装箱的装箱或卸载目前一直采用人工操作。Logistics warehousing is a key link in modern intelligent logistics, which plays an important role in connection, transfer, storage, storage and other links, while warehousing management also occupies a core position in logistics warehousing. The precise warehouse process generally includes receiving goods, putting on shelves , Picking up, replenishing, shipping, and inventorying several processes. In order to realize intelligent distribution, automatic guided transport vehicles appear in the prior art, that is, equipped with automatic guiding devices such as electromagnetic or optical, and have safety protection and various moving parts. The transport vehicle with loading function does not require a driver in logistics and warehousing applications. It uses rechargeable batteries as its power source. Generally, it can control its travel route and behavior through a computer, or use electromagnetic rails to set up its travel route to realize the storage of goods. However, the stacking operation of loading and unloading goods in the process of container transportation for replenishment or delivery in and out of the warehouse is still a large number of manual operations, that is, operators drive forklifts to load and unload, especially for container cargo transportation. Depending on the destination of transportation, all kinds of small-package goods are first packed in medium-sized transport boxes that are convenient for transportation and then loaded into freight containers. However, how to make a reasonable layout to maximize the space utilization of containers The layout makes the container convenient for multi-destination transportation, etc. Container problems and sorting problems during unloading have caused the packing or unloading of containers to be manually operated until now.
这种传统的人工操作装箱或卸载的生产方式存在以下缺陷:This traditional manual operation of packing or unloading has the following defects:
1.虽然入库工序或出库工序已实现自动化操作,但集装箱的装箱或卸载仍采用人工操作,因此物流仓储整体自动化程度降低、效率低;1. Although the warehousing process or the warehousing process has been automated, the loading or unloading of containers is still manually operated, so the overall automation of logistics and warehousing is reduced and the efficiency is low;
2.由于现有技术中入库工序或出库工序通常采用自动导引运输车或输送带进行传输,人工操作装箱或卸载的速度要跟上入库或出库的速度才能保证仓储转运的效率,因此操作人员劳动强度较大;2. Since the warehousing process or the warehousing process in the prior art is usually transported by automatic guided transport vehicles or conveyor belts, the speed of manual packing or unloading must keep up with the speed of warehousing or warehousing to ensure the storage and transshipment Efficiency, so the labor intensity of the operator is relatively high;
3.操作人员的责任心、情绪等人为因素对装卸进度的影响较大。3. Human factors such as the operator's sense of responsibility and emotion have a greater impact on the progress of loading and unloading.
发明内容Contents of the invention
针对上述现有技术存在的问题,本发明提供一种适用于货运集装箱的物流取码系统,自动化程度较高,能够实现智能操作、提高装卸效率,特别适用于物流仓储的集装运输中针对货运集装箱的装卸货物码放操作。Aiming at the problems existing in the above-mentioned prior art, the present invention provides a logistics code fetching system suitable for freight containers, which has a high degree of automation, can realize intelligent operation, and improve loading and unloading efficiency, and is especially suitable for logistics warehousing container transportation for freight Container loading and unloading cargo stacking operation.
为了实现上述目的,本适用于货运集装箱的物流取码系统包括装卸平台、装卸装置、分拣装置和电控装置;In order to achieve the above purpose, the logistics code retrieval system suitable for freight containers includes a loading and unloading platform, a loading and unloading device, a sorting device and an electric control device;
所述的装卸平台上在前后方向上设有平行设置的纵向导轨,纵向导轨至少延伸至装卸平台的前端;The loading and unloading platform is provided with longitudinal guide rails arranged in parallel in the front and rear directions, and the longitudinal guide rails extend at least to the front end of the loading and unloading platform;
所述的装卸装置包括支撑底架、带式输送机和叉装机;The loading and unloading device includes a support chassis, a belt conveyor and a forklift;
支撑底架的底部设有行走部,行走部包括支撑辊轮组和辊轮组驱动;支撑辊轮组包括左右对称设置的支撑辊轮,支撑辊轮与纵向导轨配合并架设在纵向导轨上,支撑辊轮组沿支撑底架前后方向设置为多组、且至少一组支撑辊轮组上设有辊轮组驱动,支撑底架通过支撑辊轮组架设安装在纵向导轨上;支撑底架的前端具有开放的U形开口结构;The bottom of the support chassis is provided with a running part, the running part includes a support roller set and a roller set drive; the support roller set includes left and right symmetrical support rollers, and the support rollers cooperate with the longitudinal guide rail and are erected on the longitudinal guide rail. The support rollers are arranged in multiple groups along the front and back directions of the support chassis, and at least one set of support rollers is provided with a roller drive, and the support chassis is erected and installed on the longitudinal guide rail through the support rollers; The front end has an open U-shaped opening structure;
带式输送机沿支撑底架前后方向架设在支撑底架上,带式输送机包括主动滚筒、从动滚筒、托辊组、输送带和底架输送机电控机构;托辊组架设安装在主动滚筒和从动滚筒之间,输送带首尾连接缠绕在主动滚筒、从动滚筒和托辊组上呈上下层结构,主动滚筒上设有滚筒驱动,底架输送机电控机构包括底架输送机控制器和与底架输送机控制器电连接的底架输送机动力电源,滚筒驱动与底架输送机控制器电连接;所述的辊轮组驱动与底架输送机控制器电连接;The belt conveyor is erected on the supporting chassis along the front and rear directions of the supporting chassis. The belt conveyor includes driving rollers, driven rollers, idler rollers, conveyor belts and the electric control mechanism of the chassis conveyor; the idler rollers are erected and installed on Between the driving roller and the driven roller, the conveyor belt is connected end to end and wound on the driving roller, the driven roller and the idler roller group to form an upper and lower structure. The driving roller is equipped with a roller drive, and the electric control mechanism of the bottom frame conveyor includes the bottom frame conveying machine controller and the underframe conveyor power supply electrically connected with the underframe conveyor controller, the roller drive is electrically connected with the underframe conveyor controller; the roller set drive is electrically connected with the underframe conveyor controller;
叉装机包括支撑平台、滑移部、叉装部、叉装机液压机构和叉装机电控机构;支撑平台位于带式输送机的正上方,支撑平台具有向下伸出的支撑腿,支撑平台通过支撑腿架设安装在支撑底架上;The forklift machine includes a support platform, a sliding part, a forklift part, a forklift machine hydraulic mechanism and a forklift machine electric control mechanism; the support platform is located directly above the belt conveyor, and the support platform has supporting legs protruding downward. The supporting legs are erected and installed on the supporting chassis;
滑移部设置在支撑平台的支撑腿与支撑底架之间,包括互相配合的导向滑轨和导向轮;导向滑轨前后方向水平设置在支撑底架上、且导向滑轨前端向前延伸至支撑底架的U形开口位置的左右两侧板上;导向轮与支撑平台的支撑腿底端安装连接,导向轮上设有导向轮驱动;The sliding part is arranged between the support legs of the support platform and the support chassis, including guide rails and guide wheels that cooperate with each other; the front and rear directions of the guide rails are horizontally arranged on the support chassis, and the front ends of the guide rails extend forward to The left and right sides of the U-shaped opening position of the support chassis; the guide wheels are installed and connected with the bottom ends of the support legs of the support platform, and the guide wheels are provided with guide wheels for driving;
叉装部包括门架、货叉架和货叉;门架包括配合套接安装的内门架和外门架,内门架和外门架之间设有门架导向机构,外门架的后下部铰接连接于支撑平台的前端,外门架通过门架俯仰液压缸与支撑平台连接,内门架通过门架升降液压缸与外门架连接,通过控制门架升降液压缸的伸缩可以实现内门架沿门架导向机构自外门架底端向下伸出或向上缩入动作;货叉架通过叉架导向机构与内门架的前端面滑动贴合连接、且货叉架的架体通过叉架升降液压缸与内门架连接,货叉架上还设有扫码识别装置和距离传感器;货叉左右对称设置为两件、通过货叉滑移导向机构架设安装在货叉架上,且货叉通过左右方向设置的货叉推移部件与货叉架安装连接;The fork loading part includes the mast, the fork frame and the fork; The rear lower part is hingedly connected to the front end of the support platform, the outer mast is connected to the support platform through the mast pitching hydraulic cylinder, and the inner mast is connected to the outer mast through the mast lifting hydraulic cylinder, which can be realized by controlling the extension and contraction of the mast lifting hydraulic cylinder. The inner mast extends downward or retracts upward from the bottom of the outer mast along the mast guide mechanism; The body is connected with the inner mast through the fork frame lifting hydraulic cylinder, and the fork frame is also equipped with a code scanning identification device and a distance sensor; , and the fork is installed and connected to the fork frame through the fork moving parts arranged in the left and right directions;
叉装机液压机构包括安装在支撑平台上的液压泵站和控制阀组,液压泵站通过液压管路与控制阀组连接,控制阀组通过液压管路分别与门架升降液压缸、门架俯仰液压缸和叉架升降液压缸连接;The hydraulic mechanism of the forklift machine includes a hydraulic pump station and a control valve group installed on the support platform. The hydraulic pump station is connected to the control valve group through hydraulic pipelines. The hydraulic cylinder is connected with the fork lifting hydraulic cylinder;
叉装机电控机构包括叉装机控制器、叉装机动力电源、定位坐标移动控制回路、距离反馈控制回路、货叉档距调节回路、转载控制回路,叉装机控制器分别与压装机动力电源、叉装机液压机构的控制阀组、货叉推移部件、货叉架上的扫码识别装置和距离传感器电连接;The electric control mechanism of the forklift machine includes the forklift machine controller, the power supply of the forklift machine, the positioning coordinate movement control circuit, the distance feedback control circuit, the fork gap adjustment circuit, and the reloading control circuit. The control valve group of the installed hydraulic mechanism, the moving part of the fork, the code scanning identification device on the fork frame and the distance sensor are electrically connected;
所述的分拣装置包括设置在装卸装置左右两侧的多个分拣机械臂和机械臂电控机构,分拣机械臂架设安装在装卸平台上,分拣机械臂至少包括左右方向移动设置的X坐标驱动、前后方向移动设置的Y坐标驱动和竖直方向移动设置的Z坐标驱动,分拣机械臂的末节设有包括抓取机构的抓取码放机械手,机械臂电控机构包括机械臂控制器和与机械臂控制器电连接的机械臂动力电源,X坐标驱动、Y坐标驱动和Z坐标驱动分别与机械臂控制器电连接;The sorting device includes a plurality of sorting manipulators arranged on the left and right sides of the loading and unloading device and the electric control mechanism of the manipulators. X-coordinate drive, Y-coordinate drive set for forward and backward movement, and Z-coordinate drive set for vertical movement. device and the mechanical arm power supply electrically connected with the mechanical arm controller, the X coordinate drive, the Y coordinate drive and the Z coordinate drive are respectively electrically connected with the mechanical arm controller;
所述的电控装置包括工业控制计算机、支撑底架控制回路、带式输送机控制回路、叉装机控制回路、分拣码放控制回路;工业控制计算机包括数据输入输出端口,工业控制计算机分别与底架输送机控制器、叉装机控制器和机械臂控制器电连接。The electric control device includes an industrial control computer, a support chassis control circuit, a belt conveyor control circuit, a fork loader control circuit, and a sorting and stacking control circuit; the industrial control computer includes data input and output ports, and the industrial control computer is connected to the bottom The frame conveyor controller, the forklift controller and the mechanical arm controller are electrically connected.
作为本发明的进一步改进方案,所述的支撑平台的底平面距离带式输送机的上层输送带的上表面之间的高度尺寸大于货物包装箱的高度尺寸。As a further improvement of the present invention, the height dimension between the bottom plane of the support platform and the upper surface of the upper conveyor belt of the belt conveyor is greater than the height dimension of the cargo packing box.
作为本发明的进一步改进方案,所述的支撑平台分为上下两部分,门架的外门架的后下部铰接连接于支撑平台的上部分前端、支撑腿安装在支撑平台的下部分上,支撑平台的上下两部分之间通过回转支承进行连接,回转支承上设有回转支承液压驱动,回转支承液压驱动通过液压管路与叉装机液压机构的控制阀组连接;所述的叉装机电控机构还包括支撑平台回转回路。As a further improvement of the present invention, the support platform is divided into upper and lower parts, the rear lower part of the outer mast of the door frame is hingedly connected to the front end of the upper part of the support platform, and the support legs are installed on the lower part of the support platform. The upper and lower parts of the platform are connected through a slewing bearing, and the slewing bearing is provided with a hydraulic drive for the slewing bearing, and the hydraulic drive of the slewing bearing is connected with the control valve group of the hydraulic mechanism of the forklift through the hydraulic pipeline; the electric control mechanism of the forklift It also includes a support platform slewing circuit.
作为本发明的优选方案,所述的沿支撑底架前后方向设置为多组的支撑辊轮组沿支撑底架前后方向均布设置、且至少两组支撑辊轮组上设有辊轮组驱动,且每个支撑辊轮上均设有回转轴线竖直方向设置的辊轮回转驱动,辊轮回转驱动可以实现支撑辊轮的滚动方向在前后方向和左右方向之间变换,辊轮回转驱动与底架输送机控制器电连接;所述的前后方向上平行设置的纵向导轨设置为多组,相邻两组平行设置的纵向导轨之间X坐标值的距离大于货运集装箱的宽度尺寸,装卸平台上在左右方向上还设有数量与支撑辊轮组相同的、平行设置的、与纵向导轨交叉呈田字格结构的横向导轨,且相邻两件横向导轨之间的距离与前后方向上支撑辊轮组之间的轴间距尺寸相同;所述的电控装置还包括支撑底架平移回路。As a preferred solution of the present invention, the support roller sets arranged in multiple sets along the front-to-back direction of the support chassis are uniformly arranged along the front-to-back direction of the support chassis, and at least two sets of support roller sets are provided with roller set driving , and each support roller is equipped with a roller rotation drive set in the vertical direction of the rotation axis. The roller rotation drive can realize the rolling direction of the support roller between the front and rear direction and the left and right direction. The roller rotation drive and The chassis conveyor controller is electrically connected; the longitudinal guide rails arranged in parallel in the front and rear directions are arranged in multiple groups, and the distance between the X coordinate values between adjacent two groups of parallel longitudinal guide rails is greater than the width of the freight container, and the loading and unloading platform In the left and right directions, there are also horizontal guide rails with the same number as the support roller set, parallel to the vertical guide rails, and crossed with the longitudinal guide rails to form a matt structure, and the distance between two adjacent horizontal guide rails is the same as that supported in the front and rear direction. The axial spacing between the roller sets is the same size; the electric control device also includes a support chassis translation circuit.
作为本发明的进一步改进方案,所述的货叉架上还包括模式识别传感器,所述的电控装置还包括叉装位置定位控制回路,所述的工业控制计算机与模式识别传感器电连接。As a further improvement of the present invention, the fork frame further includes a pattern recognition sensor, the electric control device further includes a fork position positioning control circuit, and the industrial control computer is electrically connected to the pattern recognition sensor.
作为本发明的进一步改进方案,所述的数据输入输出端口还包括无线收发模块,所述的电控装置还包括无线收发控制回路。As a further improvement solution of the present invention, the data input and output ports further include a wireless transceiver module, and the electric control device further includes a wireless transceiver control circuit.
作为本发明的进一步改进方案,所述的货叉上设有侧夹板。As a further improvement of the present invention, the fork is provided with a side splint.
作为本发明的进一步改进方案,所述的滑移部的导向滑轨是贯穿支撑底架左右两侧板的导向通槽结构。As a further improvement of the present invention, the guide rails of the sliding part are guide groove structures that run through the left and right side plates of the support chassis.
作为本发明货叉推移部件的一种实施方式,所述的货叉推移部件包括货叉推移伺服电机和水平架设安装在货叉架上的双向螺旋杆,双向螺旋杆与货叉推移伺服电机连接、且双向螺旋杆左右两端杆体上具有旋向相反的螺旋丝杠结构,所述的货叉上设有与双向螺旋杆配合安装在双向螺旋杆上的丝母,货叉推移伺服电机与电控装置的工业控制计算机电连接。As an embodiment of the fork pushing part of the present invention, the fork pushing part includes a fork pushing servo motor and a two-way screw rod installed horizontally on the fork frame, and the two-way screw rod is connected with the fork pushing servo motor , and the rod body at the left and right ends of the two-way screw rod has a screw screw structure with opposite rotation direction. The fork is provided with a screw nut that is matched with the two-way screw rod and installed on the two-way screw rod. The industrial control computer of the control device is electrically connected.
作为本发明货叉推移部件的另一种实施方式,所述的货叉推移部件包括水平架设安装在货叉架上的、伸缩方向相反设置的两件货叉推移液压缸,两件货叉推移液压缸的伸缩端分别与两件货叉连接,两件货叉推移液压缸分别与叉装机液压机构的控制阀组通过液压管路连接。As another embodiment of the pallet fork pushing part of the present invention, the pallet fork pushing part includes two hydraulic cylinders for pushing the fork that are installed horizontally on the fork frame and set in opposite telescopic directions. The telescopic ends of the hydraulic cylinders are respectively connected with two pallet forks, and the two pallet fork pushing hydraulic cylinders are respectively connected with the control valve group of the hydraulic mechanism of the forklift machine through hydraulic pipelines.
与现有技术相比,本适用于货运集装箱的物流取码系统是完全数字化控制单元,可以与智能物流的数字总线无缝连接实现集中数字化管理,配合智能物流的自动导引运输车可以实现完全数字化装卸;由于装卸装置包括支撑底架、带式输送机和叉装机,带式输送机包括底架输送机电控机构,叉装机包括叉装机电控机构,分拣装置包括设置在装卸装置左右两侧的多个分拣机械臂和机械臂电控机构,均完全采用电脑控制自动化操作,因此通过数据输入输出端口向电控装置的工业控制计算机输入货运集装箱的货物装箱位置信息、配载方案、货物包装箱码放坐标位置、货物包装箱尺寸、货运集装箱内部尺寸等数据信息后,工业控制计算机可根据已输入的配载方案通过底架输送机电控机构控制支撑底架在纵向导轨上前后坐标移动,装箱操作时通过机械臂控制器和叉装机控制器控制分拣机械臂、带式输送机和叉装机协同作业,可以实现位于装卸平台上的货物包装箱的码放坐标位置定点抓取、货物包装箱的平移码放至输送带上、货物包装箱的输送带运输、货物包装箱在货运集装箱内部的叉装与装卸码放,卸车操作时通过机械臂控制器和叉装机控制器控制叉装机、带式输送机和分拣机械臂协同作业,可以实现位于货运集装箱内部的货物包装箱的叉装、货物包装箱的码放至输送带上、货物包装箱的输送带运输、货物包装箱的平移码放至装卸平台上的货物包装箱码放坐标位置,货物包装箱叉装过程中叉装机控制器根据输入的货物包装箱尺寸控制货叉推移部件动作使货叉之间的档距调节至配合货物包装箱尺寸的设定宽度尺寸,并根据已输入的信息及货叉架上的扫码识别装置和距离传感器的反馈信息,建立叉装位置和叉装深度数学模型,然后根据数学模型控制叉装机液压机构使门架俯仰液压缸、叉架升降液压缸动作进行叉装装卸,完全电脑控制自动化操作可避免因操作人员责任心、情绪等人为因素对生产进度的影响,同时可免受操作人员操作技能熟练程度的限制,完全避免了人工操作存在的弊端,能够实现智能操作、提高装卸效率,特别适用于物流仓储的集装运输中针对货运集装箱的装卸货物码放操作。Compared with the existing technology, the logistics code retrieval system suitable for freight containers is a completely digital control unit, which can be seamlessly connected with the digital bus of intelligent logistics to realize centralized digital management, and can realize complete Digital loading and unloading; since the loading and unloading device includes a supporting chassis, a belt conveyor and a forklift, the belt conveyor includes an electric control mechanism for the chassis conveyor, the forklift includes an electric control mechanism for the forklift, and the sorting device includes The multiple sorting manipulators on both sides and the electric control mechanisms of the manipulators are fully computer-controlled and automated. Therefore, through the data input and output ports, the information on the packing position and loading of the cargo container is input to the industrial control computer of the electric control device. After the data information such as the plan, the coordinate position of the cargo packing box, the size of the cargo packing box, and the internal size of the freight container, the industrial control computer can control the supporting chassis on the longitudinal guide rail through the electric control mechanism of the chassis conveyor according to the input loading scheme. Front and rear coordinate movement, during packing operation, the robot arm controller and forklift controller control the sorting robot arm, belt conveyor and forklift machine to work together, which can realize the fixed-point grasping of the coordinate position of the stacking box on the loading and unloading platform Pick-up, translational stacking of cargo packaging boxes on the conveyor belt, conveyor belt transportation of cargo packaging boxes, fork loading and loading and unloading of cargo packaging boxes inside the freight container, during unloading operations, the fork is controlled by the controller of the mechanical arm and the controller of the forklift machine The loading machine, belt conveyor and sorting robot arm work together to realize the fork loading of the cargo packaging boxes inside the freight container, the stacking of the cargo packaging boxes on the conveyor belt, the conveyor belt transportation of the cargo packaging boxes, and the unpacking of the cargo packaging boxes. Translate and stack to the coordinate position of the cargo packaging box on the loading and unloading platform. During the fork loading process of the cargo packaging box, the forklift controller controls the movement of the fork pushing parts according to the input cargo packaging box size, so that the distance between the forks is adjusted to match the cargo. Set the width of the packing box size, and according to the input information and the feedback information from the scanning code identification device on the fork frame and the distance sensor, establish the mathematical model of fork loading position and fork loading depth, and then control the forklift machine according to the mathematical model The hydraulic mechanism makes the gantry pitching hydraulic cylinder and the fork frame lifting hydraulic cylinder move for fork loading and unloading. The complete computer-controlled automatic operation can avoid the influence of human factors such as the operator's sense of responsibility and emotion on the production progress, and at the same time avoid the operator's operation The limitation of skill proficiency completely avoids the disadvantages of manual operation, and can realize intelligent operation and improve loading and unloading efficiency. It is especially suitable for loading and unloading cargo stacking operations for freight containers in container transportation of logistics and warehousing.
附图说明Description of drawings
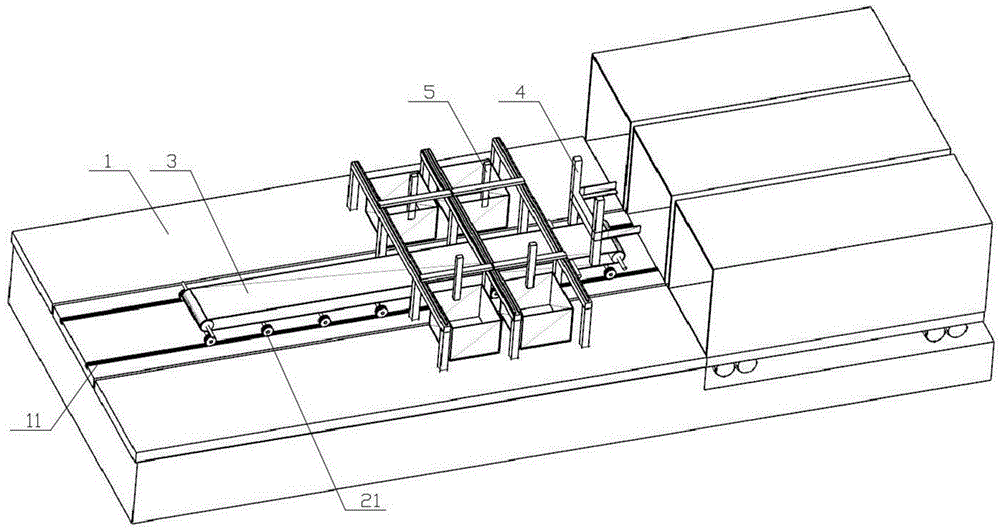
图1是本发明进行装卸货运集装箱时的三维结构示意图;Fig. 1 is the three-dimensional structure schematic diagram when the present invention carries out loading and unloading freight container;
图2是本发明叉装机在带式输送机上叉装或码放货物包装箱工作时的结构示意图;Fig. 2 is a structural schematic view of the fork loader of the present invention when it is working on a belt conveyor for fork loading or stacking cargo packaging boxes;
图3是本发明叉装机载着货物包装箱前移工作时的结构示意图;Fig. 3 is a schematic diagram of the structure of the forklift of the present invention when it is carrying a cargo packing box and moving forward;
图4是本发明叉装机在货运集装箱内部叉装或码放货物包装箱工作时的结构示意图;Fig. 4 is a schematic structural view of the fork loader of the present invention when fork loading or stacking cargo packaging boxes inside the freight container;
图5是本发明采用支撑平台回转的方式进行叉装或码放货物包装箱工作时的结构示意图;Fig. 5 is a schematic diagram of the structure of the present invention when the support platform is rotated to carry out fork-loading or stacking of cargo packaging boxes;
图6是图4的俯视图。FIG. 6 is a top view of FIG. 4 .
图中:1、装卸平台,11、纵向导轨,2、支撑底架,21、行走部,3、带式输送机,4、叉装机,41、支撑平台,42、滑移部,43、叉装部,431、门架,432、货叉架,433、货叉,5、分拣机械臂。In the figure: 1. Loading and unloading platform, 11. Longitudinal guide rail, 2. Supporting chassis, 21. Traveling part, 3. Belt conveyor, 4. Fork loader, 41. Supporting platform, 42. Sliding part, 43. Fork Mounting department, 431, door frame, 432, cargo fork frame, 433, cargo fork, 5, sorting mechanical arm.
具体实施方式detailed description
下面结合附图对本发明做进一步说明(以下以叉装部43面向货运集装箱的方向为前方描述)。The present invention will be further described below in conjunction with the accompanying drawings (below with the
如图1所示,本适用于货运集装箱的物流取码系统包括装卸平台1、装卸装置、分拣装置和电控装置。As shown in FIG. 1 , the logistics code retrieval system suitable for freight containers includes a loading and unloading platform 1 , a loading and unloading device, a sorting device and an electric control device.
所述的装卸平台1上在前后方向上设有平行设置的纵向导轨11,纵向导轨11至少延伸至装卸平台1的前端。The loading and unloading platform 1 is provided with parallel
如图2、图5、图6所示,所述的装卸装置包括支撑底架2、带式输送机3和叉装机4。As shown in FIGS. 2 , 5 and 6 , the loading and unloading device includes a
支撑底架2的底部设有行走部21,行走部21包括支撑辊轮组和辊轮组驱动;支撑辊轮组包括左右对称设置的支撑辊轮,支撑辊轮与纵向导轨11配合并架设在纵向导轨11上,支撑辊轮组沿支撑底架2前后方向设置为多组、且至少一组支撑辊轮组上设有辊轮组驱动,支撑底架2通过支撑辊轮组架设安装在纵向导轨11上;支撑底架2的前端具有开放的U形开口结构,U行开口结构便于叉装机4的上下叉装操作、避免运动干涉;The bottom of the
带式输送机3沿支撑底架2前后方向架设在支撑底架2上,带式输送机3包括主动滚筒、从动滚筒、托辊组、输送带和底架输送机电控机构;托辊组架设安装在主动滚筒和从动滚筒之间,输送带首尾连接缠绕在主动滚筒、从动滚筒和托辊组上呈上下层结构,主动滚筒上设有滚筒驱动,底架输送机电控机构包括底架输送机控制器和与底架输送机控制器电连接的底架输送机动力电源,滚筒驱动与底架输送机控制器电连接;所述的辊轮组驱动与底架输送机控制器电连接;The
叉装机4包括支撑平台41、滑移部42、叉装部43、叉装机液压机构和叉装机电控机构;支撑平台41位于带式输送机3的正上方,支撑平台41具有向下伸出的支撑腿,支撑平台41通过支撑腿架设安装在支撑底架2上;The
滑移部42设置在支撑平台41的支撑腿与支撑底架2之间,包括互相配合的导向滑轨和导向轮;导向滑轨前后方向水平设置在支撑底架2上、且导向滑轨前端向前延伸至支撑底架2的U形开口位置的左右两侧板上;导向轮与支撑平台41的支撑腿底端安装连接,导向轮上设有导向轮驱动;The sliding
叉装部43包括门架431、货叉架432和货叉433;门架431包括配合套接安装的内门架和外门架,内门架和外门架之间设有门架导向机构,外门架的后下部铰接连接于支撑平台41的前端,外门架通过门架俯仰液压缸与支撑平台41连接,通过控制门架俯仰液压缸的伸缩可以实现门架431整体沿其铰接轴前后方向俯仰动作,内门架通过门架升降液压缸与外门架连接,通过控制门架升降液压缸的伸缩可以实现内门架沿门架导向机构自外门架底端向下伸出或向上缩入动作;货叉架432通过叉架导向机构与内门架的前端面滑动贴合连接、且货叉架432的架体通过叉架升降液压缸与内门架连接,通过控制叉架升降液压缸的伸缩可以实现货叉架432沿叉架导向机构在内门架上上下移动动作,货叉架432上还设有扫码识别装置和距离传感器;货叉433左右对称设置为两件、通过货叉滑移导向机构架设安装在货叉架432上,且货叉433通过左右方向设置的货叉推移部件与货叉架432安装连接,通过控制货叉推移部件的动作可以实现货叉433之间档距的调节;The fork-mounting
叉装机液压机构包括安装在支撑平台41上的液压泵站和控制阀组,液压泵站通过液压管路与控制阀组连接,控制阀组通过液压管路分别与门架升降液压缸、门架俯仰液压缸和叉架升降液压缸连接;The hydraulic mechanism of the forklift machine includes a hydraulic pump station and a control valve group installed on the
叉装机电控机构包括叉装机控制器、叉装机动力电源、定位坐标移动控制回路、距离反馈控制回路、货叉档距调节回路、转载控制回路,叉装机控制器分别与压装机动力电源、叉装机液压机构的控制阀组、货叉推移部件、货叉架432上的扫码识别装置和距离传感器电连接。The electric control mechanism of the forklift machine includes the forklift machine controller, the power supply of the forklift machine, the positioning coordinate movement control circuit, the distance feedback control circuit, the fork gap adjustment circuit, and the reloading control circuit. The control valve group of the installed hydraulic mechanism, the fork pushing parts, the code scanning identification device on the
所述的分拣装置包括设置在装卸装置左右两侧的多个分拣机械臂5和机械臂电控机构,分拣机械臂5架设安装在装卸平台1上,分拣机械臂5至少包括左右方向移动设置的X坐标驱动、前后方向移动设置的Y坐标驱动和竖直方向移动设置的Z坐标驱动,分拣机械臂5的末节设有包括抓取机构的抓取码放机械手,机械臂电控机构包括机械臂控制器和与机械臂控制器电连接的机械臂动力电源,X坐标驱动、Y坐标驱动和Z坐标驱动分别与机械臂控制器电连接。The sorting device includes a plurality of sorting
所述的电控装置包括工业控制计算机、支撑底架控制回路、带式输送机控制回路、叉装机控制回路、分拣码放控制回路;工业控制计算机包括数据输入输出端口,工业控制计算机分别与底架输送机控制器、叉装机控制器和机械臂控制器电连接。The electric control device includes an industrial control computer, a support chassis control circuit, a belt conveyor control circuit, a fork loader control circuit, and a sorting and stacking control circuit; the industrial control computer includes data input and output ports, and the industrial control computer is connected to the bottom The frame conveyor controller, the forklift controller and the mechanical arm controller are electrically connected.
本适用于货运集装箱的物流取码系统在初始状态时,支撑底架2停滞在装卸平台1的前端边缘的设定位置,叉装机4停滞在带式输送机3上方的设定叉装坐标位置。In the initial state of the logistics code retrieval system applicable to freight containers, the supporting
本适用于货运集装箱的物流取码系统的工作原理:将载有货运集装箱的车辆停靠在装卸平台1下的、箱门正对叉装机4的设定位置后,此时货运集装箱的底板即与装卸平台1的上平面平齐,操作人员进行对接后打开箱门,同时操作人员通过工业控制计算机的数据输入输出端口向工业控制计算机输入货运集装箱的货物装箱位置信息、配载方案、货物包装箱码放坐标位置、货物包装箱尺寸、货运集装箱内部尺寸数据信息。The working principle of the logistics code retrieval system applicable to freight containers: After the vehicle carrying the freight container is parked under the loading and unloading platform 1, and the door of the container is facing the set position of the
装箱操作时,支撑底架控制回路首先开始工作;工业控制计算机根据已输入的配载方案、货物包装箱尺寸和货运集装箱内部尺寸数据信息计算支撑底架2前移进入货运集装箱6内部的深度、并将该支撑底架2需前移的Y坐标值发送给底架输送机控制器,同时向底架输送机控制器发出支撑底架前进动作控制指令,底架输送机控制器控制辊轮组驱动动作使支撑辊轮组拖载着支撑底架2向前坐标移动至上述计算的支撑底架2前移的Y坐标值,支撑底架2前移过程中支撑底架2前端的辊轮组脱离纵向导轨11、越过装卸平台1与货运集装箱的对接位置进入货运集装箱6内部的设定位置并定位,底架输送机控制器实时向工业控制计算机反馈数据信息;During the packing operation, the control circuit of the support chassis first starts to work; the industrial control computer calculates the depth at which the
需装箱的货物首先通过自动导引运输车按照配载方案依次运输至分拣机械臂5附近的设定货物包装箱码放坐标位置,然后分拣码放控制回路首先工作;工业控制计算机向机械臂控制器发出抓取码放控制指令,机械臂控制器控制分拣机械臂5坐标移动使抓取码放机械手移动至货物包装箱码放坐标位置的正上方、并沿Z坐标下移对货物进行抓取;抓取后机械臂控制器控制分拣机械臂5坐标移动使抓取码放机械手载着货物沿Z坐标上移至货物包装箱的底平面距离装卸平台1之间的距离尺寸大于带式输送机3的上层输送带的上表面距离装卸平台1之间的距离尺寸的设定Z坐标位置;然后机械臂控制器控制分拣机械臂5坐标移动使抓取码放机械手载着货物沿X坐标平移至设定距离,该设定距离是货物包装箱码放坐标位置与带式输送机3的输送带宽度中心之间的X坐标值;然后机械臂控制器控制抓取码放机械手沿Z坐标下移对货物进行码放;机械臂控制器实时向工业控制计算机反馈数据信息;The goods that need to be packed are first transported to the set coordinates of the cargo packing box near the sorting
然后带式输送机控制回路开始工作;工业控制计算机根据已输入货物包装箱尺寸和货物包装箱码放坐标位置数据信息计算货物包装箱需前移至设定叉装坐标位置的Y坐标值、并将该货物包装箱需前移的Y坐标值发送给底架输送机控制器,同时向底架输送机控制器发出带式输送机动作控制指令,底架输送机控制器控制滚筒驱动动作使主动滚筒正向旋转带动上层输送带载着货物包装箱前移至设定叉装坐标位置后停止,底架输送机控制器实时向工业控制计算机反馈数据信息;Then the belt conveyor control circuit starts to work; the industrial control computer calculates the Y coordinate value that the cargo packaging box needs to move forward to the coordinate position of the fork loading according to the input cargo packaging box size and the coordinate position data information of the cargo packaging box, and The Y coordinate value of the cargo packing box that needs to be moved forward is sent to the bottom frame conveyor controller, and at the same time sends a belt conveyor action control command to the bottom frame conveyor controller, and the bottom frame conveyor controller controls the driving action of the roller to make the active roller The positive rotation drives the upper conveyor belt to move forward carrying the cargo packing box to the set fork loading coordinate position and then stops, and the bottom frame conveyor controller feeds back data information to the industrial control computer in real time;
然后叉装机控制回路开始工作;工业控制计算机向叉装机控制器发出叉装机叉装动作控制指令,叉装机控制器首先根据输入的货物包装箱尺寸信息控制货叉推移部件动作使货叉433之间的档距调节至配合货物包装箱尺寸的设定宽度尺寸;然后叉装机控制器根据已输入的货物包装箱尺寸信息和货叉架432上的扫码识别装置的反馈识别信息建立货物叉装位置和叉装深度数学模型;如图2所示,然后叉装机控制器根据数学模型控制叉装机液压机构使门架升降液压缸、门架俯仰液压缸、叉架升降液压缸协同动作对位于带式输送机3上层输送带上的设定叉装坐标位置的货物包装箱进行叉装使其脱离带式输送机3,叉装过程中货叉架432上的距离传感器实时反馈货叉架432与货物之间的距离以保证叉装深度;如图3所示,完成货物叉装后叉装机控制器根据配载方案及货物装箱位置信息、货运集装箱内部尺寸数据信息计算支撑平台41需前移的Y坐标值、并控制滑移部42的导向轮驱动动作使支撑平台41前移至该Y坐标值的码放位置,如图4所示,然后叉装机控制器控制叉装机液压机构使门架升降液压缸、门架俯仰液压缸、叉架升降液压缸协同动作对位于货叉433上的货物包装箱进行卸载使其码放在货物装箱位置信息中设定的货物装箱位置,最后叉装机4恢复至初始状态即完成一次码放、准备进行后续的码放;码放装箱过程中叉装机控制器实时向工业控制计算机反馈数据信息;Then the forklift control circuit starts to work; the industrial control computer sends a forklift action control command to the forklift controller. The gear distance is adjusted to match the set width size of the cargo packaging box; then the forklift controller establishes the cargo fork loading position according to the input cargo packaging box size information and the feedback identification information of the scanning code identification device on the
以此类推,工业控制计算机根据叉装机控制器实时反馈的数据信息适时对底架输送机控制器发出支撑底架回退动作控制指令控制支撑底架2步进回退,直至支撑底架2的前端完全退出货运集装箱、且全部货物包装箱按照配载方案在货运集装箱内部全部码放整齐,完成整个装箱过程。By analogy, according to the data information fed back by the forklift controller in real time, the industrial control computer sends a support chassis retraction action control command to the chassis conveyor controller in good time to control the
卸车操作是装箱操作的反过程,操作人员通过工业控制计算机的数据输入输出端口除了向工业控制计算机输入货运集装箱的货物装箱位置信息、配载方案、货物包装箱尺寸、货运集装箱内部尺寸数据信息以外,还向工业控制计算机输入分拣信息,分拣信息包括根据不同的分拣条件分配的不同的货物包装箱码放坐标位置信息;The unloading operation is the reverse process of the packing operation. The operator inputs the cargo packing position information, loading plan, cargo packing box size, and internal size data of the freight container to the industrial control computer through the data input and output ports of the industrial control computer. In addition to the information, the sorting information is also input to the industrial control computer. The sorting information includes the coordinate position information of different cargo packaging boxes allocated according to different sorting conditions;
叉装机控制回路首先开始工作,叉装机控制器根据配载方案和货物装箱位置信息控制叉装部43对货运集装箱内部的货物包装箱进行叉装后回退至初始位置,然后叉装机控制器控制叉装部43将货物包装箱码放在位于带式输送机3上层输送带上的设定叉装坐标位置,叉装机控制器实时向工业控制计算机反馈数据信息;The control loop of the forklift starts to work first, and the forklift controller controls the
工业控制计算机根据叉装机控制器反馈的货叉架432上的扫码识别装置的反馈识别信息和已输入的分拣信息向底架输送机控制器发送带式输送机动作指令,然后带式输送机控制回路开始工作,底架输送机控制器控制滚筒驱动动作使主动滚筒反向旋转带动上层输送带载着货物包装箱后移至该货物包装箱对应的货物包装箱码放坐标位置Y坐标的设定坐标位置后停止;The industrial control computer sends the belt conveyor action command to the chassis conveyor controller according to the feedback identification information of the scanning code recognition device on the
然后分拣码放控制回路开始工作,工业控制计算机向对应货物包装箱码放坐标位置的机械臂控制器发出抓取码放控制指令,机械臂控制器控制分拣机械臂5坐标移动使抓取码放机械手对货物包装箱进行抓取并X坐标方向平移后码放在货物包装箱码放坐标位置上,自动导引运输车即可对该货物包装箱进行运输;Then the sorting and stacking control loop starts to work, and the industrial control computer sends a grabbing and stacking control command to the robotic arm controller corresponding to the coordinate position of the cargo packaging box. The cargo packaging box is grabbed and translated in the X coordinate direction and placed on the coordinate position of the cargo packaging box, and the automatic guided transport vehicle can transport the cargo packaging box;
以此类推,工业控制计算机根据叉装机控制器实时反馈的数据信息适时对底架输送机控制器发出支撑底架前进动作控制指令控制支撑底架2步进前进,直至支撑底架2的前端完全进入货运集装箱、且全部货物包装箱按照配载方案全部卸载,完成整个卸车过程,支撑底架2回退至初始状态即可。By analogy, according to the data information fed back by the forklift controller in real time, the industrial control computer sends a control command to the chassis conveyor controller to control the forward movement of the
为了简化控制,作为本发明的进一步改进方案,所述的支撑平台41的底平面距离带式输送机3的上层输送带的上表面之间的高度尺寸大于货物包装箱的高度尺寸,即,货物包装箱装卸过程中叉装部43始终面向前方,采取只控制叉装机4前后移动的方式对货物包装箱进行叉装和码放,在带式输送机3的上层输送带载着货物包装箱前移或后移时货物包装箱自支撑平台41下方经过。In order to simplify the control, as a further improvement of the present invention, the height dimension between the bottom plane of the
为了缩短滑移部42的导向滑轨的长度、同时降低支撑平台41的高度,进而实现更稳固地叉装,作为本发明的进一步改进方案,如图5所示,所述的支撑平台41分为上下两部分,门架431的外门架的后下部铰接连接于支撑平台41的上部分前端、支撑腿安装在支撑平台41的下部分上,支撑平台41的上下两部分之间通过回转支承进行连接,回转支承上设有回转支承液压驱动,回转支承液压驱动通过液压管路与叉装机液压机构的控制阀组连接,通过控制回转支承液压驱动的动作可以实现支撑平台41的上部分相对于支撑平台41的下部分进行旋转;所述的叉装机电控机构还包括支撑平台回转回路;货物包装箱装卸过程中采取支撑平台41带动叉装部43回转的方式对货物包装箱进行叉装和码放,如此设置可以使,支撑平台41的底平面贴近带式输送机3的上层输送带,进而大大降低支撑平台41的高度、实现更稳固地叉装,同时,回转的方式可以使支撑平台41前后移动的距离相对减小,进而实现缩短滑移部42的导向滑轨的长度。In order to shorten the length of the guide rails of the sliding
为了提高装卸效率,通常采用载有货运集装箱的车辆在完成装卸后直接开走更换下一辆载有货运集装箱的车辆进行装卸的方式,即通过移动货运集装箱的方式,也可以采用多个装卸工位、平移载有货运集装箱的车辆的方式,或者采用平移装卸装置的方式,由于第一种方式装卸装置需等待车辆进入装卸车位后才能进行装卸,而第二种方案实现平移载有货运集装箱的车辆相对较困难、需额外设置平移托载设施,而第三种方案在设有多个装卸车位的情况下可以实现一个装卸车位进行装卸的过程中可以进行装卸车辆的补充、进而实现装卸装置连续作业、效率相对前二者较高,因此优选第三种方案,即,作为本发明的优选方案,本适用于货运集装箱的物流取码系统采用多装卸车位、本身自移的方式,所述的沿支撑底架2前后方向设置为多组的支撑辊轮组沿支撑底架2前后方向均布设置、且至少两组支撑辊轮组上设有辊轮组驱动,且每个支撑辊轮上均设有回转轴线竖直方向设置的辊轮回转驱动,辊轮回转驱动可以实现支撑辊轮的滚动方向在前后方向和左右方向之间变换,辊轮回转驱动与底架输送机控制器电连接;所述的前后方向上平行设置的纵向导轨11设置为多组,相邻两组平行设置的纵向导轨11之间X坐标值的距离大于货运集装箱的宽度尺寸,装卸平台1上在左右方向上还设有数量与支撑辊轮组相同的、平行设置的、与纵向导轨11交叉呈田字格结构的横向导轨,且相邻两件横向导轨之间的距离与前后方向上支撑辊轮组之间的轴间距尺寸相同;所述的电控装置还包括支撑底架平移回路;当本适用于货运集装箱的物流取码系统完成一个货运集装箱的装卸后回退至初始位置,支撑底架平移回路开始工作,工业控制计算机控制底架输送机控制器使所有的辊轮回转驱动同时同方向旋转90°,则所有的辊轮全部由前后方向变换为左右方向,然后底架输送机控制器控制辊轮回转驱动动作使支撑辊轮组拖载着支撑底架2向左或向右坐标移动X坐标值的距离至另外一个装卸工位,然后工业控制计算机控制底架输送机控制器使所有的辊轮回转驱动同时同方向旋转90°恢复成前后方向,即可在此装卸工位上进行装卸操作。In order to improve loading and unloading efficiency, the vehicle carrying the freight container is usually used to drive away directly after loading and unloading to replace the next vehicle carrying the freight container for loading and unloading, that is, by moving the freight container, multiple stevedores can also be used Positioning and translation of vehicles carrying freight containers, or the use of translation loading and unloading devices, because the first method of loading and unloading devices needs to wait for the vehicle to enter the loading and unloading space before loading and unloading, while the second scheme realizes the translation of freight containers. The vehicle is relatively difficult, and additional translational supporting facilities are required, while the third scheme can realize the supplement of loading and unloading vehicles in the process of loading and unloading in one loading and unloading parking space in the case of multiple loading and unloading spaces, and then realize the continuous loading and unloading device. The operation and efficiency are relatively higher than the former two, so the third option is preferred, that is, as the preferred option of the present invention, the logistics code retrieval system suitable for freight containers adopts the method of multi-loading and unloading parking spaces and self-moving itself. Along the front and back direction of the
为了保证准确叉装,作为本发明的进一步改进方案,所述的货叉架432上还包括模式识别传感器,所述的叉装机电控机构还包括叉装位置定位控制回路,所述的叉装机电控机构的叉装机控制器与模式识别传感器电连接;叉装机控制器根据货物包装箱尺寸信息及模式识别传感器反馈的货物位置信息建立货物模式识别数据模型,并将该货物模式识别数据模型与已建立的叉装位置和叉装深度数学模型进行纠偏整合,最后根据纠偏整合后的数学模型控制叉装机液压机构使门架升降液压缸、门架俯仰液压缸、叉架升降液压缸协同动作进行叉装。In order to ensure accurate fork loading, as a further improvement of the present invention, the
为了实现更快捷的实时数据交换和控制、提高装卸效率,作为本发明的进一步改进方案,所述的数据输入输出端口还包括无线收发模块,所述的电控装置还包括无线收发控制回路;工业控制计算机通过无线收发模块和无线收发控制回路可以在装卸前利用无线传输自上端网络接收货运集装箱的货物装箱位置信息、配载方案、货物包装箱码放坐标位置、货物包装箱尺寸、货运集装箱内部尺寸等数据信息,并在装卸过程中实现实时向上端网络反馈装卸具体情况,一方面可以实现配合自动导引运输车在装箱过程中自装卸平台上进行定点叉装、在卸车过程中在装卸平台上进行定点码放,缩短了本物流取码车在叉装码放过程中行走的路程、提高装卸效率;另一方面操作人员可以对本物流取码车进行实时远程控制纠偏。In order to achieve faster real-time data exchange and control, and improve loading and unloading efficiency, as a further improvement of the present invention, the data input and output ports also include a wireless transceiver module, and the electronic control device also includes a wireless transceiver control circuit; Through the wireless transceiver module and the wireless transceiver control circuit, the control computer can use wireless transmission to receive the cargo packing position information, stowage plan, coordinate position of the cargo packaging box, cargo packaging box size, and the interior of the freight container from the upper-end network before loading and unloading. Size and other data information, and realize real-time feedback of loading and unloading details to the upper-end network during the loading and unloading process. The fixed-point stacking on the platform shortens the distance traveled by the logistics code pickup truck during fork loading and stacking, and improves the loading and unloading efficiency; on the other hand, the operator can perform real-time remote control and correction of the logistics code pickup truck.
为了防止叉装过程中货物包装箱自货叉433左右两侧意外滑落,作为本发明的进一步改进方案,所述的货叉433上设有侧夹板,侧夹板分别左右对称设置在左右对称设置的两件货叉433的左右两侧;针对重量较小的货物包装箱,在完成货物包装箱的叉装后,叉装机控制器控制货叉档距调节回路再次工作使货叉433的档距缩小,进而实现侧夹板对货物包装箱的夹持。In order to prevent the cargo packaging box from accidentally slipping from the left and right sides of the
为了保证滑移部42的导向滑轨在叉装货物包装箱时能够提供稳固的支撑导向,作为本发明的进一步改进方案,所述的滑移部42的导向滑轨是贯穿支撑底架2左右两侧板的导向通槽结构。In order to ensure that the guide rails of the sliding
针对货物宽度尺寸与货运集装箱内部的宽度尺寸配合的情况,作为本发明货叉推移部件的一种实施方式,所述的货叉推移部件包括货叉推移伺服电机和水平架设安装在货叉架432上的双向螺旋杆,双向螺旋杆与货叉推移伺服电机连接、且双向螺旋杆左右两端杆体上具有旋向相反的螺旋丝杠结构,所述的货叉433上设有与双向螺旋杆配合安装在双向螺旋杆上的丝母,货叉推移伺服电机与叉装机电控机构的叉装机控制器电连接;通过叉装机控制器控制货叉推移伺服电机的正反转可以实现货叉433之间档距的调节。For the case where the width of the cargo matches the width of the interior of the freight container, as an embodiment of the fork pushing part of the present invention, the fork pushing part includes a fork pushing servo motor and a horizontal erection installed on the
针对尺寸较小的货物包装箱,为了提高货运集装箱内部的空间利用率,作为本发明货叉推移部件的另一种实施方式,所述的货叉推移部件包括水平架设安装在货叉架432上的、伸缩方向相反设置的两件货叉推移液压缸,两件货叉推移液压缸的伸缩端分别与两件货叉433连接,两件货叉推移液压缸分别与叉装机液压机构的控制阀组通过液压管路连接;通过叉装机控制器控制叉装机液压机构使两件货叉推移液压缸的伸出长度不同可以实现货叉433之间档距的调节和货叉433的偏载位置。In order to improve the space utilization rate inside the freight container for smaller cargo packaging boxes, as another embodiment of the fork pushing part of the present invention, the fork pushing part includes horizontal erection and installation on the
本适用于货运集装箱的物流取码系统是完全数字化控制单元,可以与智能物流的数字总线无缝连接实现集中数字化管理,配合智能物流的自动导引运输车可以实现完全数字化装卸;由于装卸装置包括支撑底架2、带式输送机3和叉装机4,带式输送机3包括底架输送机电控机构,叉装机4包括叉装机电控机构,分拣装置包括设置在装卸装置左右两侧的多个分拣机械臂5和机械臂电控机构,均完全采用电脑控制自动化操作,因此通过数据输入输出端口向电控装置的工业控制计算机输入货运集装箱的货物装箱位置信息、配载方案、货物包装箱码放坐标位置、货物包装箱尺寸、货运集装箱内部尺寸等数据信息后,工业控制计算机可根据已输入的配载方案通过底架输送机电控机构控制支撑底架2在纵向导轨11上前后坐标移动,装箱操作时通过机械臂控制器和叉装机控制器控制分拣机械臂5、带式输送机3和叉装机4协同作业,可以实现位于装卸平台1上的货物包装箱的码放坐标位置定点抓取、货物包装箱的平移码放至输送带上、货物包装箱的输送带运输、货物包装箱在货运集装箱内部的叉装与装卸码放,卸车操作时通过机械臂控制器和叉装机控制器控制叉装机4、带式输送机3和分拣机械臂5协同作业,可以实现位于货运集装箱内部的货物包装箱的叉装、货物包装箱的码放至输送带上、货物包装箱的输送带运输、货物包装箱的平移码放至装卸平台1上的货物包装箱码放坐标位置,货物包装箱叉装过程中叉装机控制器根据输入的货物包装箱尺寸控制货叉推移部件动作使货叉433之间的档距调节至配合货物包装箱尺寸的设定宽度尺寸,并根据已输入的信息及货叉架432上的扫码识别装置和距离传感器的反馈信息,建立叉装位置和叉装深度数学模型,然后根据数学模型控制叉装机液压机构使门架俯仰液压缸、叉架升降液压缸动作进行叉装装卸,完全电脑控制自动化操作可避免因操作人员责任心、情绪等人为因素对生产进度的影响,同时可免受操作人员操作技能熟练程度的限制,完全避免了人工操作存在的弊端,能够实现智能操作、提高装卸效率,特别适用于物流仓储的集装运输中针对货运集装箱的装卸货物码放操作。The logistics code retrieval system suitable for freight containers is a completely digital control unit, which can be seamlessly connected with the digital bus of intelligent logistics to realize centralized digital management, and can realize complete digital loading and unloading with the automatic guided transport vehicle of intelligent logistics; since the loading and unloading device includes Support the
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201710680948.XA CN107352207B (en) | 2017-08-10 | 2017-08-10 | Logistics code-fetching system suitable for freight container |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201710680948.XA CN107352207B (en) | 2017-08-10 | 2017-08-10 | Logistics code-fetching system suitable for freight container |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN107352207A CN107352207A (en) | 2017-11-17 |
| CN107352207B true CN107352207B (en) | 2023-01-03 |
Family
ID=60287892
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201710680948.XA Active CN107352207B (en) | 2017-08-10 | 2017-08-10 | Logistics code-fetching system suitable for freight container |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN107352207B (en) |
Families Citing this family (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN108341273A (en) * | 2017-12-21 | 2018-07-31 | 深圳市鸿益达供应链科技有限公司 | Full-automatic de-stacking system |
| WO2019213900A1 (en) * | 2018-05-10 | 2019-11-14 | 深圳蓝胖子机器人有限公司 | Cargo loading/unloading vehicle, cargo transfer system, and automatic leveling method for cargo loading/unloading vehicle |
| CN109592445B (en) * | 2018-08-09 | 2022-11-15 | 麒麟(山东)智能设备制造有限公司 | Efficient container body stacking system and method |
| CN110901675B (en) * | 2018-09-14 | 2021-07-20 | 中车唐山机车车辆有限公司 | Train underframe supporting equipment |
| US11402830B2 (en) * | 2018-09-28 | 2022-08-02 | Teradyne, Inc. | Collaborative automation logistics facility |
| CN111285123A (en) * | 2018-12-07 | 2020-06-16 | 沈阳阿尔洛科技有限公司 | Intelligent loading system |
| CN110697625B (en) * | 2019-09-16 | 2024-09-03 | 福州国化智能技术有限公司 | A cargo loading and unloading system for a quick-opening side curtain box |
| CN110624837A (en) * | 2019-10-11 | 2019-12-31 | 深圳市格雷柏智能装备股份有限公司 | A continuous vertical sorting system |
| IT202000029687A1 (en) * | 2020-12-03 | 2022-06-03 | S Cube Srl | SYSTEM FOR THE AUTOMATIC CONNECTION AND/OR DISCONNECTION OF THE ELECTRICITY SUPPLY AND/OR THE DATA CONNECTION FOR REFRIGERATED CONTAINERS |
| CN112686067A (en) * | 2020-12-30 | 2021-04-20 | 博纬智能科技(无锡)有限公司 | Real-time cargo detection method and system based on image and radio frequency identification |
| CN118790924B (en) * | 2024-09-12 | 2025-02-07 | 苏州荣世吉自动化设备有限公司 | A height-adjustable self-propelled loading and unloading device and loading and unloading method thereof |
Family Cites Families (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR100557350B1 (en) * | 2004-07-06 | 2006-03-03 | 이완영 | Loading and unloading rack of palletless cargo storage system |
| FI126245B (en) * | 2005-03-09 | 2016-08-31 | Konecranes Finland Oy | Procedure for placing a palletless goods package on a warehouse shelf and handing it over therefrom and administering the package logistics and equipment for carrying out the procedure |
| SG10201503147RA (en) * | 2010-04-30 | 2015-06-29 | David Alba | System for the transfer, storage and distribution of intermodal containers |
| DE102011089858A1 (en) * | 2011-12-23 | 2013-06-27 | Krones Ag | System for transporting goods arranged on auxiliary means |
| CN103466333B (en) * | 2013-09-03 | 2016-01-20 | 中国科学院深圳先进技术研究院 | Automation palletizing system |
| CN103879704B (en) * | 2014-04-22 | 2015-12-30 | 山东兰剑物流科技股份有限公司 | A kind of light-duty hopper high-speed buck stacker |
| CN104649019B (en) * | 2015-02-09 | 2016-08-31 | 张帆 | The fast automatic shipping stacker of container |
| CN105923409B (en) * | 2016-06-25 | 2019-03-29 | 佛山隆深机器人有限公司 | Fully automatic container handling system |
| CN207293220U (en) * | 2017-08-10 | 2018-05-01 | 徐州德坤电气科技有限公司 | Suitable for the logistics code fetch system of freight container |
-
2017
- 2017-08-10 CN CN201710680948.XA patent/CN107352207B/en active Active
Also Published As
| Publication number | Publication date |
|---|---|
| CN107352207A (en) | 2017-11-17 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN107352206B (en) | Sorting device and sorting method for logistics code fetching system | |
| CN107352207A (en) | A kind of logistics code fetch system suitable for freight container | |
| CN107298272B (en) | Handling device of code system is got in commodity circulation | |
| CN107380869A (en) | A kind of application method of logistics code fetch system suitable for freight container | |
| CN111137808B (en) | Carrier trolley | |
| CN107352278B (en) | A kind of control method of loading and unloading device of logistics code fetching system | |
| CN210162598U (en) | A storage sorting system | |
| CN110697625B (en) | A cargo loading and unloading system for a quick-opening side curtain box | |
| CN107499802A (en) | A kind of application method of logistics code fetch car suitable for freight container | |
| CN104724431A (en) | Inner-outer-vehicle-embedded three-dimensional walking rail guided vehicle | |
| CN107311081B (en) | A logistics code picking vehicle suitable for freight containers | |
| CN211768039U (en) | Warehousing system | |
| CN106005862A (en) | Automatic storage warehouse equipment | |
| CN108045825A (en) | A kind of rotatable load bed shuttle for carrying manipulator | |
| CN110255222B (en) | Intelligent cargo loading device and cargo loading method | |
| CN210504790U (en) | Intelligent loading device | |
| CN112758577B (en) | Multi-station storage, picking and stacking conveyor and stacking method | |
| CN110271801A (en) | A kind of vertical rotary cabinet and Intelligent logistics warehousing system | |
| CN111532638A (en) | Unmanned storehouse system | |
| CN207293221U (en) | The handler of logistics code fetch system | |
| CN209758208U (en) | A multi-intensive shuttle warehouse online sorting hoist | |
| CN212862674U (en) | Shuttle car goods integration lifting machine, access system and warehouse entry storage, access letter sorting and warehouse entry storage letter sorting packing integration system | |
| CN207726112U (en) | A kind of rotatable load bed shuttle carrying manipulator | |
| CN108840122A (en) | A kind of automatic loading machine | |
| CN207293222U (en) | Logistics code fetch system sorting equipment |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20251212 Address after: 266000, No. 8 Xi'an Road, Liyuan Street Office, Pingdu City, Qingdao City, Shandong Province, Room 404, Building 18, Area C, 218 (Concentrated Office Area) Patentee after: Qingdao Jinlun Huitong Logistics Co.,Ltd. Country or region after: China Address before: B1012, 10th Floor, Zone B, University Pioneer Park, High tech Zone, No. 99, University Road, Tongshan District, Xuzhou City, Jiangsu Province, 221000 Patentee before: XUZHOU DKEC ELECTRICAL TECNOLOGY Co.,Ltd. Country or region before: China |
|
| TR01 | Transfer of patent right |