EP4200092B1 - Verfahren zum zuführen eines materialbandes zur bearbeitungszone einer werkzeugmaschine - Google Patents
Verfahren zum zuführen eines materialbandes zur bearbeitungszone einer werkzeugmaschine Download PDFInfo
- Publication number
- EP4200092B1 EP4200092B1 EP20781479.9A EP20781479A EP4200092B1 EP 4200092 B1 EP4200092 B1 EP 4200092B1 EP 20781479 A EP20781479 A EP 20781479A EP 4200092 B1 EP4200092 B1 EP 4200092B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- material strip
- feed
- feed rollers
- profile
- standstill
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B21—MECHANICAL METAL-WORKING WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D—WORKING OR PROCESSING OF SHEET METAL OR METAL TUBES, RODS OR PROFILES WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D43/00—Feeding, positioning or storing devices combined with, or arranged in, or specially adapted for use in connection with, apparatus for working or processing sheet metal, metal tubes or metal profiles; Associations therewith of cutting devices
- B21D43/02—Advancing work in relation to the stroke of the die or tool
- B21D43/04—Advancing work in relation to the stroke of the die or tool by means in mechanical engagement with the work
- B21D43/08—Advancing work in relation to the stroke of the die or tool by means in mechanical engagement with the work by rollers
- B21D43/09—Advancing work in relation to the stroke of the die or tool by means in mechanical engagement with the work by rollers by one or more pairs of rollers for feeding sheet or strip material
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B26—HAND CUTTING TOOLS; CUTTING; SEVERING
- B26D—CUTTING; DETAILS COMMON TO MACHINES FOR PERFORATING, PUNCHING, CUTTING-OUT, STAMPING-OUT OR SEVERING
- B26D7/00—Details of apparatus for cutting, cutting-out, stamping-out, punching, perforating, or severing by means other than cutting
- B26D7/06—Arrangements for feeding or delivering work of other than sheet, web, or filamentary form
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B21—MECHANICAL METAL-WORKING WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D—WORKING OR PROCESSING OF SHEET METAL OR METAL TUBES, RODS OR PROFILES WITHOUT ESSENTIALLY REMOVING MATERIAL; PUNCHING METAL
- B21D43/00—Feeding, positioning or storing devices combined with, or arranged in, or specially adapted for use in connection with, apparatus for working or processing sheet metal, metal tubes or metal profiles; Associations therewith of cutting devices
- B21D43/02—Advancing work in relation to the stroke of the die or tool
- B21D43/04—Advancing work in relation to the stroke of the die or tool by means in mechanical engagement with the work
- B21D43/06—Advancing work in relation to the stroke of the die or tool by means in mechanical engagement with the work by positive or negative engaging parts co-operating with corresponding parts of the sheet or the like to be processed, e.g. carrier bolts or grooved section in the carriers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B26—HAND CUTTING TOOLS; CUTTING; SEVERING
- B26F—PERFORATING; PUNCHING; CUTTING-OUT; STAMPING-OUT; SEVERING BY MEANS OTHER THAN CUTTING
- B26F1/00—Perforating; Punching; Cutting-out; Stamping-out; Apparatus therefor
- B26F1/02—Perforating by punching, e.g. with relatively-reciprocating punch and bed
- B26F1/14—Punching tools; Punching dies
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H20/00—Advancing webs
- B65H20/20—Advancing webs by web-penetrating means, e.g. pins
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H23/00—Registering, tensioning, smoothing or guiding webs
- B65H23/04—Registering, tensioning, smoothing or guiding webs longitudinally
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2301/00—Handling processes for sheets or webs
- B65H2301/40—Type of handling process
- B65H2301/44—Moving, forwarding, guiding material
- B65H2301/449—Features of movement or transforming movement of handled material
- B65H2301/4493—Features of movement or transforming movement of handled material intermittent
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2301/00—Handling processes for sheets or webs
- B65H2301/50—Auxiliary process performed during handling process
- B65H2301/51—Modifying a characteristic of handled material
- B65H2301/512—Changing form of handled material
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2515/00—Physical entities not provided for in groups B65H2511/00 or B65H2513/00
- B65H2515/30—Forces; Stresses
- B65H2515/32—Torque e.g. braking torque
Definitions
- the present invention relates to a method for feeding a material strip to the processing zone of a machine tool, as well as to a machine tool with a feed device according to the preamble of independent patent claim 8.
- the clamping of the material strip between the feed rollers is temporarily released so that the material strip can temporarily move freely. This process is also known as "intermediate release".
- pilot pins are then inserted into assigned pilot openings in the material strip, which then position the material strip precisely. Before the pilot pins are extended from the pilot openings, the material strip is clamped between the feed rollers again so that it is fixed in a precisely aligned state.
- the task here is therefore to provide a technical solution which does not have the disadvantages of the state of the art described above or at least partially avoids them.
- a first aspect of the invention relates to a method for feeding a material strip to the processing zone of a punching press.
- the feed rollers are driven by one or more servo motors, whereby the servo motor(s) and thus the feed rollers driven by them are controlled per feed interval with a controller according to a specified target movement and standstill profile.
- Servo motors are particularly well suited for this purpose because they can be precisely controlled in terms of their drive and holding torques as well as their rotation positions.
- the target movement and standstill profile of the servo motor(s) or the feed rollers is synchronized with the movement profile of the press ram.
- the actual movement and standstill profile of the servo motor(s) or the feed rollers is monitored and the target movement and standstill profile of a subsequent feed interval, in particular the next feed interval, is shifted in such a way that the target position of the servo motor(s) or the feed rollers at the start of this shifted target movement and standstill profile corresponds to the actual position of the servo motor(s) or the feed rollers after positioning the material strip with the pilot pin(s).
- a target value adjustment takes place after each feed interval, which prevents an accumulation of target value deviations over several feed intervals.
- the method according to the invention makes it possible to achieve a highly precise belt feed even without complex intermediate release mechanisms.
- the holding torque in process step b) is temporarily reduced to a certain value greater than zero, The material belt can only be moved by overcoming the reduced holding torque. If the holding torque is temporarily removed, the material belt can move freely in and against the feed direction.
- the pilot pin(s) are re-extended from the pilot openings of the material strip while the holding torque of the feed rollers is temporarily reduced or eliminated. This can prevent the pilot pins from jamming if the feed rollers are moved when the reduction or elimination of the holding torque is eliminated again. It is then also possible to eliminate the reduction or elimination of the holding torque by driving the feed rollers with a specific drive torque in order to feed the material strip, without first restoring the original holding torque when the machine is at a standstill.
- the temporary reduction or elimination of the holding torque of the feed rollers is canceled before the pilot pin(s) are moved out of the pilot openings of the material strip again, preferably by restoring the original holding torque. This can prevent the feed rollers from moving when the reduction or elimination of the holding torque is canceled again.
- the material strip is moved in the feed direction during positioning with the pilot pin(s). This is particularly advantageous when very thin material strips are processed and a reduced holding torque is used, because this way compression of the material strip can be avoided.
- the synchronization is carried out as a so-called relative synchronization is used, in which the executed part of the target movement and standstill profile of the servo motor(s) always corresponds relatively to the executed part of the movement profile of the press ram. If the press is within a feed step and the feed is synchronized in this way, it continues at the correct point of the target movement and standstill profile of the servo motor(s), i.e. it only advances by the "remaining length". The "remaining length" is moved synchronously with the movement profile of the press ram. Accordingly, the target movement and standstill profile of the servo motor or the feed rollers can be started and stopped as desired.
- the feed rollers are monitored for any rotary movement. If a setpoint tracking is carried out as described above, in which the setpoint movement and standstill profile of the next feed interval is shifted in such a way that the setpoint position of the servo motor(s) or the feed rollers at the start of this shifted setpoint movement and standstill profile corresponds to the actual position of the servo motor(s) or the feed rollers after the material strip has been positioned with the pilot pin(s), it is preferred that the monitoring begins with the start of the setpoint tracking and ends after the reduction or lifting of the holding torque has ended, i.e.
- the press when the normal holding torque is restored. If a certain maximum permissible angle of twist is detected, the press is automatically stopped and the detected angle of twist, which led to the press stop, is preferably communicated to the press operator via The press control is informed so that it can carry out a targeted error analysis.
- a second, unclaimed aspect of the invention relates to a feed device for use in carrying out the method according to the first aspect of the invention.
- the feed device comprises at least one pair of feed rollers between which the material strip can be clamped and with which it can be fed forward intermittently by intermittent rotation of the feed rollers and can be held in the feed pauses when the material strip is stationary and clamped between the feed rollers by fixing the feed rollers with a specific holding torque.
- the feed device is designed in such a way that in the feed pauses when the material strip is stationary and clamped between the feed rollers, the holding torque of the feed rollers when holding the material strip can be temporarily reduced or eliminated, so that the material strip can be displaced by forces acting on the material strip, with the feed rollers clamping the material strip being twisted by the material strip clamped between them.
- the feed device makes it possible to achieve a highly precise belt feed even without complex intermediate release mechanisms.
- the feed device is designed in such a way that the holding torque can be temporarily reduced to a certain value greater than zero. As a result, the material strip can only be moved by overcoming the reduced holding torque.
- the feed device is designed such that the holding torque can be temporarily canceled.
- one or the other alternative may be preferable.
- the feed rollers of the feed device are preferably driven by one or more servo motors.
- Servo motors are particularly suitable for this purpose because they can be precisely controlled in terms of their drive and holding torques as well as their rotation positions.
- the servo motor(s) and thus the feed rollers driven by them can be controlled per feed interval with a controller according to a predetermined target movement and standstill profile.
- a third aspect of the invention relates to a machine tool with a feed device according to the second aspect of the invention, preferably for carrying out the method according to the first aspect of the invention.
- the machine tool comprises a control with which the servo motor(s) or the feed rollers can be controlled per feed interval according to a predetermined target movement and standstill profile.
- the machine tool or a tool assigned to this machine has one or more pilot pins for insertion into assigned pilot openings in the material strip for the purpose of positioning the material strip when the holding torque is temporarily reduced or eliminated.
- the control is designed in such a way that the actual movement and standstill profile of the servo motor or the feed rollers of the feed device can be monitored and the target movement and standstill profile of a subsequent feed interval of the feed device, preferably the next feed interval, can be shifted in such a way that the target position of the servo motor or the feed rollers at the beginning of this shifted target movement and standstill profile corresponds to the actual position of the servo motor or the feed rollers after positioning the material strip with the pilot pin(s).
- a setpoint adjustment can be carried out after each feed interval, which can prevent an accumulation of setpoint deviations over several feed intervals.
- the machine tool is a punch press, wherein the desired movement and standstill profile of the servo motor or the feed rollers can be synchronized with the movement profile of the press ram.
- the synchronization is carried out as a so-called relative synchronization, in which the executed part of the target movement and standstill profile of the servo motor(s) always corresponds relatively to the executed part of the movement profile of the press ram. If the press is within a feed step and the feed is synchronized in this way, it continues at the correct point of the target movement and standstill profile of the servo motor(s), i.e. it only advances by the "remaining length". The "remaining length" is moved synchronously with the movement profile of the press ram. Accordingly, the target movement and standstill profile of the servo motor or the feed rollers can be started and stopped as desired.
- the machine tool is designed in such a way that after the pilot pin(s) have been extended from the pilot openings of the material strip and during the removal of the reduction in the holding torque of the feed rollers of the feed device, the feed rollers can be monitored for any rotational movement, and that if If a certain maximum permissible angle of twist is detected to be exceeded, the press can be stopped automatically and, advantageously, the detected angle of twist which led to the press stop can be communicated to the press operator via the press control system so that he can carry out a targeted error analysis.
- a setpoint tracking is carried out as described above, in which the setpoint movement and standstill profile of the next feed interval is shifted in such a way that the setpoint position of the servo motor(s) or the feed rollers at the beginning of this shifted setpoint movement and standstill profile corresponds to the actual position of the servo motor(s) or the feed rollers after positioning the material strip with the pilot pin(s), it is preferred that the monitoring begins with the start of the setpoint tracking and ends after the reduction or elimination of the holding torque has ended, i.e. when the normal holding torque is restored.
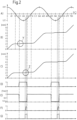
- the Figures 1 A) to G ) show the curves of various operating parameters of a punching press over the crank angle of the press when applying a first method according to the invention for feeding a material strip to the processing zone of the punching press over two crankshaft revolutions or 720° crank angle X.
- Fig. 1 A which shows the press stroke or the ram position between the top dead center TDC and the bottom dead center BDC over the crank angle X
- the press ram starting from the top dead center TDC, passes through the bottom dead center BDC at 180° and 540°, and the top dead center TDC at 360° and 720°.
- FIG. 1 B) and 1 C which shows the actual movement and standstill profile of the feed rollers ( Fig. 1B) ) and the target movement and standstill profile of the feed rollers ( Fig. 1C) ) in millimetres of the circumferential rotation of the feed rollers and thus in millimetres of the feed movement of the material strip, when passing through the top dead centre TDC up to about 90° after the TDC, an actual displacement of the material strip occurs by rotation of the feed rollers as in Fig. 1B) shown according to the specified target movement and standstill profile in Fig. 1C) .
- a feed pause begins at approximately 90° after TDC and lasts until approximately 270° after TDC or 90° after BDC.
- Fig. 1 F which shows the status of the setpoint tracking of the press control between "Off” 0 and "On” 1
- the setpoint tracking is activated at approx. 200° after TDC or approx. 20° after BDC, which is completed at approximately 215° after TDC or 35° after BDC and is then deactivated again.
- the target movement and standstill profile of the feed interval that immediately follows is shifted in such a way that the target position of the feed rollers at the start of this shifted target movement and standstill profile corresponds to the current actual position of the feed rollers after positioning the material strip with the pilot pins.
- the pilot pins are completely retracted into the pilot openings in the material strip and the feed rollers are held with the reduced holding torque.
- the pilot pins are retracted after the setpoint correction has been made at approximately 220° after TDC or 40° after BDC, and while the pilot pins are being retracted, the holding torque of the feed rollers is increased again to the original value of 1 Nm.
- Both processes ie the extension of the pilot pins from the pilot openings of the material belt and the re-increasing of the holding torque, are completed at 225° after TDC or 45° after BDC.
- this process monitoring is activated when the setpoint tracking is activated, i.e. at approx. 200° after TDC or 20° after BDC, and deactivated after the pilot pins have completely extended from the pilot openings of the material belt and the holding torque has been increased again to 1 Nm, i.e. at 225° after TDC or 45° after BDC.
- the press is automatically stopped and the operator is informed of the detected twisting angle via the press control.
- the feed pause ends and the material strip is advanced by the rotation of the feed rollers, while the press ram moves upwards towards the top dead center TDC, which it reaches at 360° after TDC or 180° after BDC. From then on, the previously described process starts again from the beginning.
- the Figures 2 A) to G ) show the curves of various operating parameters of a punching press over the crank angle of the press when applying a second method according to the invention for feeding a material strip to the processing zone of the punching press over two crankshaft revolutions or 720° crank angle X.
- the procedure according to the Figures 2 A) to G ) differs from the procedure according to the Figures 1 A) to G ) only in the fact that when the pilot pins are inserted into the pilot openings of the material strip, whereby the material strip is brought into its final processing position, the material strip is pulled or pushed forward in the feed direction and the feed rollers are turned forward accordingly.
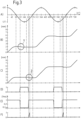
- FIGS. 3 A) to F show the curves of various operating parameters of a punching press over the crank angle of the press when applying a third method according to the invention for feeding a material strip to the processing zone of the punching press over two crankshaft revolutions or 720° crank angle X.
- the procedure according to the Figures 3 A) to F ) differs from the procedure according to the Figures 1 A) to G ) by activating the setpoint tracking after the pilot pins have been completely retracted and the holding torque of the feed rollers has returned to the original value of 1 Nm. In this process, this is the case at approximately 225° after TDC or 45° after BDC. In this embodiment, the process monitoring according to Fig. 1 G) .
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Life Sciences & Earth Sciences (AREA)
- Forests & Forestry (AREA)
- Advancing Webs (AREA)
- Punching Or Piercing (AREA)
- Registering, Tensioning, Guiding Webs, And Rollers Therefor (AREA)
Description
- Die vorliegende Erfindung betrifft ein Verfahren zum Zuführen eines Materialbandes zur Bearbeitungszone einer Werkzeugmaschine, sowie eine Werkzeugmaschine mit einem Vorschubapparat gemäss dem Oberbegriff des unabhängigen Patentanspruchs 8.
- Bei Werkzeugmaschinen, auf denen ein Materialband in mehreren Schritten bearbeitet wird, ist es oft erforderlich, ein bestimmtes Vorschubmass präzise einzuhalten. Insbesondere bei Stanzautomaten, auf denen im Folgeschnittverfahren aus einem Materialband Produkte ausgestanzt werden, sind extrem geringe Toleranzen gefordert, welche über die Steuerung der Vorschubwalzen der verwendeten Vorschübe nicht mehr sicherzustellen sind.
- Um hier die geforderten Toleranzen einhalten zu können, wird die Klemmung des Materialbandes zwischen den Vorschubwalzen vorübergehend aufgehoben, so dass das Materialband vorübergehend frei beweglich ist. Dieser Vorgang wird auch als "Zwischenlüften" bezeichnet. In diesem frei beweglichen Zustand werden dann Pilotstifte in zugeordnete Pilotöffnungen in dem Materialband eingefahren, welche das Materialband dann exakt positionieren. Vor dem Ausfahren der Pilotstifte aus den Pilotöffnungen wird das Materialband wieder zwischen den Vorschubwalzen geklemmt, so dass es in einem exakt ausgerichteten Zustand fixiert ist.
- Dieses bekannte Verfahren ermöglicht zwar eine bezüglich des Vorschubmasses hochpräzise Bandverarbeitung, weist jedoch den Nachteil auf, dass die hierfür erforderlichen Vorschubapparate mechanisch sehr aufwendig und entsprechend teuer und unterhaltsintensiv sind.
- Aus
CN 110 479 895 A , auf welche der Oberbegriff des Patentanspruchs 8 basiert, ist ein Verfahren sowie eine Vorrichtung bekannt, bei welchen kein "Zwischenlüften" der Walzen erfolgt, sondern diese für das Einfahren der Pilotstifte vorübergehend drehmomentfrei geschaltet werden. - Es stellt sich hier deshalb die Aufgabe, eine technische Lösung zur Verfügung zu stellen, welche die zuvor beschriebenen Nachteile des Standes der Technik nicht aufweist oder zumindest teilweise vermeidet.
- Diese Aufgabe wird durch die Gegenstände der unabhängigen Patentansprüche gelöst.
- Gemäss diesen betrifft ein erster Aspekt der Erfindung ein Verfahren zum Zuführen eines Materialbandes zur Bearbeitungszone einer Stanzpresse.
- Dabei wird das Materialband zwischen mindestens einem Paar von Vorschubwalzen permanent eingespannt und durch intervallweises Rotieren der Vorschubwalzen intervallweise vorgeschoben. Es erfolgt also kein Zwischenlüften der Vorschubwalzen. Nach jedem Vorschieben des Materialbandes werden in der Vorschubpause bis zum nächsten Vorschieben des Materialbandes die folgenden Schritte durchgeführt:
- a) Halten des Materialbandes durch Festlegen der Vorschubwalzen mit einem bestimmten Haltemoment.
- b) vorübergehendes Reduzieren oder Aufheben des Haltemoments der Vorschubwalzen.
- c) Positionieren des Materialbandes bei reduziertem oder aufgehobenen Haltemoment der Vorschubwalzen durch Einfahren eines oder mehrerer Pilotstifte in zugeordnete Pilotöffnungen im Materialband. Dabei wird das Materialband, wenn eine Abweichung von der Soll-Position vorliegt bzw. die Pilotstifte und die Pilotöffnungen nicht deckungsgleich sind, durch den oder die Pilotstifte verschoben und die Vorschubwalzen werden durch das zwischen ihnen eingespannte Materialband bei dessen Verschiebung verdreht, gegebenenfalls unter Überwindung des reduzierten Haltemoments.
- d) Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes.
- Dabei werden die Vorschubwalzen mit einem oder mehreren Servomotoren angetrieben, wobei der oder die Servomotoren und damit die von diesen angetriebenen Vorschubwalzen pro Vorschubintervall mit einer Steuerung gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert werden. Servomotoren eignen sich besonders gut für diesen Zweck weil sie bezüglich ihrer Antriebs- und Haltemomente wie auch bezüglich ihrer Verdrehpositionen präzise ansteuerbar sind.
- Das Soll-Bewegungs- und Stillstandsprofil des oder der Servomotoren bzw. der Vorschubwalzen ist mit dem Bewegungsprofil des Pressenstössels synchronisiert.
- Das Ist-Bewegungs- und Stillstandsprofil des oder der Servomotoren bzw. der Vorschubwalzen wird überwacht und das Soll-Bewegungs- und Stillstandsprofil eines folgenden Vorschubintervalls, insbesondere des nächsten Vorschubintervalls, wird derartig verschoben, dass die Soll-Position des oder der Servomotoren bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des oder der Servomotoren bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht. Auf diese Weise erfolgt dann nach jedem Vorschubintervall eine Sollwertnachführung, wodurch ein Kumulieren von Sollwertabweichungen über mehrere Vorschubintervalle hinweg verhindert wird.
- Mit dem erfindungsgemässen Verfahren wird es möglich, auch ohne aufwendige Zwischenlüft-Mechaniken einen hochpräzisen Bandvorschub zu erzielen.
- Wird das Haltemoment im Verfahrensschritt b) vorübergehend auf einen bestimmten Wert grösser Null reduziert, so kann das Materialband nur unter Überwindung des reduzierten Haltemoments bewegt werden. Wird das Haltemoment vorübergehend aufgehoben, so ist das Materialband in und entgegen der Vorschubrichtung frei beweglich.
- In einer bevorzugten Variante des Verfahrens erfolgt das Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes während das Haltemoment der Vorschubwalzen vorübergehend reduziert oder aufgehoben ist. Hierdurch kann vermieden werden, dass es bei einem eventuellen Bewegen der Vorschubrollen beim Wiederaufheben der Reduzierung oder Aufhebung des Haltemoments zu einem Verklemmen der Pilotstifte kommt. Auch ist es dann möglich, die Wiederaufhebung der Reduzierung oder Aufhebung des Haltemoments durch Antrieb der Vorschubwalzen mit einem bestimmten Antriebsmoment zwecks Vorschub des Materialbandes zu bewirken, ohne vorgängig im Stillstand erneut das ursprüngliche Haltemoment wieder herzustellen.
- In einer bevorzugten Variante des Verfahrens wird vor dem Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes die vorübergehende Reduzierung oder Aufhebung des Haltemoments der Vorschubwalzen wieder aufgehoben, bevorzugterweise indem das ursprüngliche Haltemoment wieder hergestellt wird. Hierdurch kann verhindert werden, dass es beim Wiederaufheben der Reduzierung oder Aufhebung des Haltemoments zu einem Bewegen der Vorschubrollen kommt.
- In einer weiteren bevorzugten Ausführungsform des Verfahrens wird das Materialband beim Positionieren mit dem oder den Pilotstiften in Vorschubrichtung verschoben. Dies ist insbesondere dann von Vorteil, wenn sehr dünne Materialbänder verarbeitet werden und ein reduziertes Haltemoment zum Einsatz kommt, weil auf diese Weise eine Stauchung des Materialbandes vermieden werden kann.
- Dabei ist es bevorzugt, dass die Synchronisation als sogenannte relative Synchronisation durchgeführt wird, bei welcher der ausgeführte Teil des Soll-Bewegungs- und Stillstandsprofil des oder der Servomotoren immer relativ gesehen zum ausgeführten Teil des Bewegungsprofil des Pressenstössels übereinstimmt. Steht die Presse innerhalb eines Vorschubschrittes und der Vorschub wird auf diese Weise aufsynchronisiert, so wird an der richtigen Stelle des Soll-Bewegungs- und Stillstandsprofil des oder der Servomotoren weiter gemacht, d.h. es wird also nur noch um die "Restlänge" vorgeschoben. Dabei wird die "Restlänge" synchron zum Bewegungsprofil des Pressenstössels gefahren. Entsprechend kann im Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen beliebig gestartet und gestoppt werden kann.
- In noch einer weiteren bevorzugten Ausführungsform des Verfahrens werden nach dem Ausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes und während dem Aufheben der Reduzierung des Haltemoments der Vorschubwalzen die Vorschubwalzen auf eine allfällige Drehbewegung überwacht. Wird dabei eine Sollwertnachführung wie zuvor beschrieben durchgeführt, bei welcher das Soll-Bewegungs- und Stillstandsprofil des nächsten Vorschubintervalls derartig verschoben wird, dass die Soll-Position des oder der Servomotoren bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des oder der Servomotoren bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht, so ist es bevorzugt, dass die Überwachung mit dem Start des Sollwertnachführung beginnt und nach der Beendigung der Reduzierung oder Aufhebung des Haltemoments, d.h. bei Wiederherstellung des normalen Haltemoments, endet. Wird dabei ein Überschreiten eines bestimmten max. zulässigen Verdrehwinkels festgestellt, so wird die Presse automatisch gestoppt, und mit Vorteil wird der festgestellte Verdrehwinkel, welcher zum Pressenstopp geführt hat, dem Bediener der Presse über die Pressensteuerung mitgeteilt, damit dieser gezielt eine Fehleranalyse durchführen kann.
- Ein zweiter, nicht beanspruchter Aspekt der Erfindung betrifft einen Vorschubapparat zur Verwendung bei der Durchführung des Verfahrens gemäss dem ersten Aspekt der Erfindung. Der Vorschubapparat umfasst mindestens ein Paar von Vorschubwalzen zwischen denen das Materialband eingespannt werden kann und mit denen es durch intervallweises Rotieren der Vorschubwalzen intervallweise vorgeschoben werden kann und in den Vorschubpausen bei stillstehendem und zwischen den Vorschubwalzen eingespanntem Materialband durch Festlegen der Vorschubwalzen mit einem bestimmten Haltemoment gehalten werden kann. Dabei ist der Vorschubapparat derartig ausgestaltet, dass in den Vorschubpausen bei stillstehendem und zwischen den Vorschubwalzen eingespanntem Materialband das Haltemoment der Vorschubwalzen beim Halten des Materialbandes vorübergehend reduziert oder aufgehoben werden kann, so dass das Materialband durch am Materialband angreifende Kräfte verschoben werden kann, unter einem Verdrehen der das Materialband einspannenden Vorschubwalzen durch das zwischen ihnen eingespannte Materialband.
- Mit dem Vorschubapparat wird es möglich, auch ohne aufwendige Zwischenlüft-Mechaniken einen hochpräzisen Bandvorschub zu erzielen.
- In einer bevorzugten Ausführungsform ist der Vorschubapparat derartig ausgestaltet, dass das Haltemoment vorübergehend auf einen bestimmten Wert grösser Null reduziert werden kann. Hierdurch kann das Materialband nur unter Überwindung des reduzierten Haltemoments bewegt werden.
- In einer alternativen bevorzugten Ausführungsform ist der Vorschubapparat derartig ausgestaltet, dass das Haltemoment vorübergehend aufgehoben werden kann.
- Je nach Bearbeitungsprozess und betrieblichen Gegebenheiten kann die eine oder die andere Alternative bevorzugter sein.
- Die Vorschubwalzen des Vorschubapparates sind mit Vorteil mit einem oder mehreren Servomotoren angetrieben. Servomotoren eignen sich besonders gut für diesen Zweck weil sie bezüglich ihrer Antriebs- und Haltemomente wie auch bezüglich ihrer Verdrehpositionen präzise ansteuerbar sind.
- Dabei ist es bevorzugt, dass der oder die Servomotoren und damit die von diesen angetriebenen Vorschubwalzen pro Vorschubintervall mit einer Steuerung gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert werden können.
- Ein dritter Aspekt der Erfindung betrifft eine Werkzeugmaschine mit einem Vorschubapparat gemäss dem zweiten Aspekt der Erfindung, bevorzugterweise zur Durchführung des Verfahrens gemäss dem ersten Aspekt der Erfindung. Die Werkzeugmaschine umfasst eine Steuerung mit welcher der oder die Servomotoren bzw. die Vorschubwalzen pro Vorschubintervall gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert werden können.
- Die Werkzeugmaschine bzw. ein dieser Maschine zugeordnetes Werkzeug weist einen oder mehrere Pilotstifte zum Einfahren in zugeordnete Pilotöffnungen im Materialband auf, zwecks Positionierung des Materialbandes bei vorübergehend reduziertem oder aufgehobenem Haltemoment.
- Dabei ist die Steuerung derartig ausgebildet, dass das Ist-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen des Vorschubapparates überwacht werden kann und das Soll-Bewegungs- und Stillstandsprofil eines folgenden Vorschubintervalls des Vorschubapparates, bevorzugterweise des nächsten Vorschubintervalls, derartig verschoben werden kann, dass die Soll-Position des Servomotors bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des Servomotors bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht.
- Auf diese Weise kann nach jedem Vorschubintervall eine Sollwertnachführung erfolgen, wodurch ein Kumulieren von Sollwertabweichungen über mehrere Vorschubintervalle hinweg verhindert werden kann.
- In einer besonders bevorzugten Ausführungsform ist die Werkzeugmaschine eine Stanzpresse, wobei das Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen mit dem Bewegungsprofil des Pressenstössels synchronisierbar ist.
- Dabei ist es bevorzugt, dass die Synchronisation als sogenannte relative Synchronisation ausgeführt ist, bei welcher der ausgeführte Teil des Soll-Bewegungs- und Stillstandsprofil des oder der Servomotoren immer relativ gesehen zum ausgeführten Teil des Bewegungsprofil des Pressenstössels übereinstimmt. Steht die Presse innerhalb eines Vorschubschrittes und der Vorschub wird auf diese Weise aufsynchronisiert, so wird an der richtigen Stelle des Soll-Bewegungs- und Stillstandsprofil des oder der Servomotoren weiter gemacht, d.h. es wird also nur noch um die "Restlänge" vorgeschoben. Dabei wird die "Restlänge" synchron zum Bewegungsprofil des Pressenstössels gefahren. Entsprechend kann im Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen beliebig gestartet und gestoppt werden.
- In noch einer weiteren bevorzugten Ausführungsform ist die Werkzeugmaschine derartig ausgestaltet, dass nach dem Ausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes und während dem Aufheben der Reduzierung des Haltemoments der Vorschubwalzen des Vorschubapparates die Vorschubwalzen auf eine allfällige Drehbewegung überwacht werden können, und dass, wenn dabei ein Überschreiten eines bestimmten max. zulässigen Verdrehwinkels festgestellt wird, die Presse automatisch gestoppt werden kann und mit Vorteil der festgestellte Verdrehwinkel, welcher zum Pressenstopp geführt hat, dem Bediener der Presse über die Pressensteuerung mitgeteilt werden kann, damit dieser gezielt eine Fehleranalyse durchführen kann.
- Wird dabei eine Sollwertnachführung wie zuvor beschrieben durchgeführt, bei welcher das Soll-Bewegungs- und Stillstandsprofil des nächsten Vorschubintervalls derartig verschoben wird, dass die Soll-Position des oder der Servomotoren bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des oder der Servomotoren bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht, so ist es bevorzugt, dass die Überwachung mit dem Start des Sollwertnachführung beginnt und nach der Beendigung der Reduzierung oder Aufhebung des Haltemoments, d.h. bei Wiederherstellung des normalen Haltemoments, endet.
- Weitere bevorzugte Ausführungen der Erfindung ergeben sich aus den abhängigen Ansprüchen und aus der nun folgenden Beschreibung anhand der Figuren. Diese zeigen in den
Figuren 1 A)-G ),2 A)-G ) und3 A)-F ) jeweils die Verläufe verschiedener Betriebsparameter einer Stanzpresse mit Kurbeltrieb und Pilotstiften über dem Kurbelwinkel der Presse bei der Anwendung verschiedener erfindungsgemässer Verfahren zum Zuführen eines Materialbandes zur Bearbeitungszone der Stanzpresse. Dabei zeigen die mit A) bis G) gekennzeichneten Teilfiguren die Verläufe der folgenden Betriebsparameter jeweils über dem Kurbelwinkel: - A) Pressenhub
- B) Ist-Bewegungs- und Stillstandsprofil der Vorschubwalzen
- C) Soll-Bewegungs- und Stillstandsprofil der Vorschubwalzen
- D) Position Pilotstifte
- E) Halte- bzw. Antriebsmoment der Vorschubwalzen
- F) Sollwertnachführung
- G) Prozessüberwachung
- Die
Figuren 1 A) bis G ) zeigen die Verläufe verschiedener Betriebsparameter einer Stanzpresse über dem Kurbelwinkel der Presse bei der Anwendung eines ersten erfindungsgemässen Verfahrens zum Zuführen eines Materialbandes zur Bearbeitungszone der Stanzpresse über zwei Kurbelwellenumdrehungen bzw. 720° Kurbelwinkel X. - Wie aus
Fig. 1 A) ersichtlich ist, welche den Pressenhub bzw. die Stösselposition zwischen dem oberen Totpunkt OT und dem unteren Totpunkt UT über dem Kurbelwinkel X zeigt, durchläuft der Pressenstössel ausgehend von dem oberen Totpunkt OT bei 180° und bei 540° den unteren Totpunkt UT, und bei 360° und 720° den oberen Totpunkt OT. - Wie aus den
Figuren 1 B) und 1 C ) ersichtlich ist, welche das Ist-Bewegungs- und Stillstandsprofil der Vorschubwalzen (Fig. 1 B) ) und das Soll-Bewegungs- und Stillstandsprofil der Vorschubwalzen (Fig. 1 C) ) in Millimetern der Umfangsdrehung der Vorschubwalzen und damit in Millimetern der Vorschubbewegung des Materialbandes zeigen, erfolgt beim Durchgang durch den oberen Totpunkt OT bis etwa 90° nach dem OT eine Ist-Verschiebung des Materialbandes durch Rotation der Vorschubwalzen wie inFig. 1 B) gezeigt gemäss dem vorgegebenen Soll-Bewegungs- und Stillstandsprofil inFig. 1 C) . Ab ca. 90° nach OT beginnt eine Vorschubpause, welche bis etwa 270° nach OT bzw. 90° nach UT andauert. - Wie aus den
Figuren 1 D) und 1 E ) ersichtlich ist, welche die Position der Pilotstifte die in Pilotöffnungen im Materialband eingefahren werden zwischen der vollständig zurückgezogenen Position 0 und der vollständig in die Pilotöffnungen eingefahrenen Position 1 zeigen (Fig. 1 D) ) und den Verlauf des Halte- bzw. Antriebsmoment der Vorschubwalzen in Nm zeigen (Fig. 1 E) ), beginnen die Pilotstifte in der Vorschubpause kurz vor 135° nach OT bzw. kurz vor 45° vor UT in die Pilotöffnungen einzufahren. Während dem Einfahren der Pilotstifte wird das Halte- bzw. Antriebsmoment der Vorschubwalzen, welches zuvor konstant auf 1 Nm eingestellt war, herabgesetzt auf ein reduziertes Haltemoment von 0.1 Nm. Beide Vorgänge, d.h. das Einfahren der Pilotstifte in die Pilotöffnungen des Materialbandes und das Herabsetzen des Haltemoments sind bei 135° nach OT abgeschlossen. - Wie aus dem mit Y gekennzeichneten Verlaufsversatz in
Fig. 1 B) ersichtlich ist, welcher der besseren Erkennbarkeit vergrössert dargestellt ist, erfolgt beim Einfahren der Pilotstifte in die Pilotöffnungen im Materialband, bei welchem das Materialband in seine definitive Bearbeitungsposition gebracht wird, ein Zurückschieben der Materialbandes entgegen der Vorschubrichtung und ein entsprechendes Zurückverdrehen der Vorschubwalzen, während der das Soll-Bewegungs- und Stillstandsprofil der Vorschubwalzen wie inFig. 1 C) erkennbar unverändert bleibt. - Es folgt anschliessend um den unteren Totpunkt UT herum die Stanzbearbeitung des Materialbandes, wobei die Pilotstifte vollständig in die Pilotöffnungen im Materialband eingefahren sind und das reduzierte Haltemoment der Vorschubwalzen vorliegt.
- Wie aus
Fig. 1 F) ersichtlich ist, welche den Status der Sollwertnachführung der Pressensteuerung zwischen "Aus" 0 und "Ein" 1 zeigt, wird bei ca. 200° nach OT bzw. etwa 20° nach UT die Sollwertnachführung aktiviert, welche bei ca. 215° nach OT bzw. 35° nach UT abgeschlossen ist und dann wieder deaktiviert wird. - Wie aus dem mit Z gekennzeichneten Verlaufsversatz in
Fig. 1 C) ersichtlich ist, welcher der besseren Erkennbarkeit vergrössert dargestellt ist, erfolgt beim Aktivieren der Sollwertnachführung eine Verschiebung des Soll-Bewegungs- und Stillstandsprofil des direkt darauf folgenden Vorschubintervalls derartig, dass die Soll-Position der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der vorliegenden Ist-Position der Vorschubwalzen nach dem Positionieren des Materialbandes mit den Pilotstiften entspricht. Die Pilotstifte sind dabei vollständig in die Pilotöffnungen im Materialband eingefahren und die Vorschubwalzen werden dabei mit dem reduzierten Haltemoment gehalten. - Wie aus den
Figuren 1 D) und 1 E ) ersichtlich ist, werden die Pilotstifte nach erfolgter Sollwertkorrektur bei ca. 220° nach OT bzw. 40° nach UT zurückgezogen, und während dem Zurückziehen der Pilotstifte wird das Haltemoment der Vorschubwalzen wieder auf den ursprünglichen Wert von 1 Nm erhöht. Beide Vorgänge, d.h. das Ausfahren der Pilotstifte aus den Pilotöffnungen des Materialbandes und das Wiederheraufsetzen des Haltemoments sind bei 225° nach OT bzw. 45° nach UT abgeschlossen. - Wie aus
Fig. 1 G) ersichtlich ist, welche den Status der Prozessüberwachung bezüglich einer unbeabsichtigten Verdrehung der Vorschubwalzen zwischen "Aus" 0 und "Ein" 1 zeigt, wird diese Prozessüberwachung bei Aktivierung der Sollwertnachführung aktiviert, d.h. bei ca. 200° nach OT bzw. 20° nach UT, und nach dem vollständigen Ausfahren der Pilotstifte aus den Pilotöffnungen des Materialbandes und dem Wiederheraufsetzen des Haltemoments auf 1 Nm deaktiviert, d.h. bei 225° nach OT bzw. 45° nach UT. - Wird dabei eine Verdrehung der Vorschubwalzen festgestellt, welche einen bestimmten max. zulässigen Verdrehwinkel überschreitet, wird die Presse automatisch gestoppt und es wird dem Bediener der festgestellte Verdrehwinkel über die Pressensteuerung mitgeteilt.
- Bei etwa 270° nach OT bzw. 90° nach UT endet die Vorschubpause und das Materialband wird durch Rotation der Vorschubwalzen vorgeschoben, während der Pressenstössel sich nach oben in Richtung des oberen Totpunktes OT bewegt, welchen er bei 360° nach OT bzw. 180° nach UT erreicht. Ab dann beginnt der zuvor beschriebene Ablauf von vorne.
- Die
Figuren 2 A) bis G ) zeigen die Verläufe verschiedener Betriebsparameter einer Stanzpresse über dem Kurbelwinkel der Presse bei der Anwendung eines zweiten erfindungsgemässen Verfahrens zum Zuführen eines Materialbandes zur Bearbeitungszone der Stanzpresse über zwei Kurbelwellenumdrehungen bzw. 720° Kurbelwinkel X. - Das Verfahren gemäss den
Figuren 2 A) bis G ) unterscheidet sich von dem Verfahren gemäss denFiguren 1 A) bis G ) lediglich darin, dass beim Einfahren der Pilotstifte in die Pilotöffnungen des Materialbandes, bei welchem das Materialband in seine definitive Bearbeitungsposition gebracht wird, ein Ziehen bzw. Vorschieben der Materialbandes in Vorschubrichtung erfolgt und ein entsprechendes Vorwärtsverdrehen der Vorschubwalzen. - Die
Figuren 3 A) bis F ) zeigen die Verläufe verschiedener Betriebsparameter einer Stanzpresse über dem Kurbelwinkel der Presse bei der Anwendung eines dritten erfindungsgemässen Verfahrens zum Zuführen eines Materialbandes zur Bearbeitungszone der Stanzpresse über zwei Kurbelwellenumdrehungen bzw. 720° Kurbelwinkel X. - Das Verfahren gemäss den
Figuren 3 A) bis F ) unterscheidet sich von dem Verfahren gemäss denFiguren 1 A) bis G ) dadurch, dass die Sollwertnachführung aktiviert wird, nachdem die Pilotstifte vollständig zurückgezogen sind und das Haltemoment der Vorschubwalzen wieder auf den ursprünglichen Wert von 1 Nm erhöht ist. Dies ist in diesem Verfahren bei ca. 225° nach OT bzw. 45° nach UT der Fall. Bei dieser Ausführungsform entfällt zudem die Prozessüberwachung gemässFig. 1 G) . - Während in der vorliegenden Anmeldung bevorzugte Ausführungen der Erfindung beschrieben sind, ist klar darauf hinzuweisen, dass die Erfindung nicht auf diese beschränkt ist und auch in anderer Weise innerhalb des Umfangs der nun folgenden Ansprüche ausgeführt werden kann.
Claims (16)
- Verfahren zum Zuführen eines Materialbandes zur Bearbeitungszone einer Werkzeugmaschine, insbesondere eines Stanzautomaten, wobei das Materialband zwischen mindestens einem Paar von Vorschubwalzen eingespannt wird und durch intervallweises Rotieren der Vorschubwalzen intervallweise vorgeschoben wird, und wobei nach jedem Vorschieben des Materialbandes und vor dem nächsten Vorschieben des Materialbandes in einer Vorschubpause bei stillstehendem und zwischen den Vorschubwalzen eingespanntem Materialband die folgenden Schritte durchgeführt werden:a) Halten des Materialbandes durch Festlegen der Vorschubwalzen mit einem bestimmten Haltemoment;b) vorübergehendes Reduzieren oder Aufheben des Haltemoments der Vorschubwalzen;c) Positionieren des Materialbandes bei reduziertem oder aufgehobenen Haltemoment der Vorschubwalzen durch Einfahren eines oder mehrerer Pilotstifte in zugeordnete Pilotöffnungen im Materialband, wobei das Materialband durch den oder die Pilotstifte verschoben wird und die Vorschubwalzen durch das zwischen ihnen eingespannte Materialband bei dessen Verschiebung verdreht werden, gegebenenfalls unter Überwindung des reduzierten Haltemoments; undd) Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes,wobei die Vorschubwalzen mit einem Servomotor angetrieben werden,wobei der Servomotor bzw. die Vorschubwalzen pro Vorschubintervall mit einer Steuerung gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert wird bzw. werden,wobei das Ist-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen überwacht wird und das Soll-Bewegungs- und Stillstandsprofil eines folgenden Vorschubintervalls, insbesondere des nächsten Vorschubintervalls, derartig verschoben wird, dass die Soll-Position des Servomotors bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des Servomotors bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht,wobei die Werkzeugmaschine eine Stanzpresse ist und wobei das Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen mit dem Bewegungsprofil des Pressenstössels synchronisiert ist.
- Verfahren nach Anspruch 1, wobei das Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes erfolgt während das Haltemoment der Vorschubwalzen vorübergehend reduziert oder aufgehoben ist.
- Verfahren nach Anspruch 1, wobei vor dem Wiederausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes die vorübergehende Reduzierung oder Aufhebung des Haltemoments der Vorschubwalzen wieder aufgehoben wird.
- Verfahren nach einem der vorhergehenden Ansprüche, wobei das Materialband beim Positionieren mit dem oder den Pilotstiften in Vorschubrichtung verschoben wird.
- Verfahren nach einem der vorangehenden Ansprüche, wobei die Synchronisation als relative Synchronisation durchgeführt wird, so dass im Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen beliebig gestartet und gestoppt werden kann.
- Verfahren nach einem der vorhergehenden Ansprüche, wobei nach dem Ausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes und während dem Aufheben der Reduzierung des Haltemoments der Vorschubwalzen die Vorschubwalzen auf eine allfällige Drehbewegung überwacht werden und bei Überschreiten eines bestimmten max. zulässigen Verdrehwinkels die Presse automatisch gestoppt wird, insbesondere unter einer Angabe des festgestellten Verdrehwinkels über die Pressensteuerung.
- Verfahren nach Anspruch 6, wobei die Überwachung mit dem Start der Verschiebung des folgenden Vorschubintervalls beginnt und bei Beendigung der Reduzierung oder Aufhebung des Haltemoments endet.
- Werkzeugmaschine, insbesondere zur Durchführung des Verfahrens nach einem der vorangehenden Ansprüche,mit einem Vorschubapparat umfassend mindestens ein Paar von Vorschubwalzen zwischen denen das Materialband eingespannt werden kann und mit denen es durch intervallweises Rotieren der Vorschubwalzen, insbesondere angetrieben durch einen Servomotor, intervallweise vorgeschoben werden kann und in den Vorschubpausen bei stillstehendem und zwischen den Vorschubwalzen eingespanntem Materialband durch Festlegen der Vorschubwalzen mit einem bestimmten Haltemoment gehalten werden kann, wobei der Vorschubapparat derartig ausgestaltet ist, dass in den Vorschubpausen bei stillstehendem und zwischen den Vorschubwalzen eingespanntem Materialband das Haltemoment der Vorschubwalzen vorübergehend reduziert oder aufgehoben werden kann, so dass das Materialband durch am Materialband angreifende Kräfte verschoben werden kann, unter einem Verdrehen der das Materialband einspannenden Vorschubwalzen durch das zwischen ihnen eingespannte Materialband,und mit einem oder mehreren Pilotstiften zum Einfahren in zugeordnete Pilotöffnungen im Materialband zwecks Positionierung des Materialbandes bei vorübergehend reduziertem oder aufgehobenem Haltemoment,dadurch gekennzeichnet, dass die Werkzeugmaschine eine Steuerung umfasst mit welcher der Servomotor bzw. die Vorschubwalzen pro Vorschubintervall gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert werden können,und wobei die Steuerung derartig ausgebildet ist, dass das Ist-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen überwacht werden kann und das Soll-Bewegungs- und Stillstandsprofil eines folgenden Vorschubintervalls, insbesondere des nächsten Vorschubintervalls, derartig verschoben werden kann, dass die Soll-Position des Servomotors bzw. der Vorschubwalzen zu Beginn dieses verschobenen Soll-Bewegungs- und Stillstandsprofils der Ist-Position des Servomotors bzw. der Vorschubwalzen nach dem Positionieren des Materialbandes mit dem oder den Pilotstiften entspricht.
- Werkzeugmaschine nach Anspruch 8, wobei der Vorschubapparat derartig ausgestaltet ist, dass das Haltemoment vorübergehend auf einen bestimmten Wert grösser Null reduziert werden kann.
- Werkzeugmaschine nach einem der Ansprüche 8 bis 9, wobei der Vorschubapparat derartig ausgestaltet ist, dass das Haltemoment vorübergehend aufgehoben werden kann.
- Werkzeugmaschine nach einem der Ansprüche 9 bis 10, wobei der Vorschubapparat einen Servomotor aufweist, zum Antreiben der Vorschubwalzen.
- Werkzeugmaschine nach Anspruch 11, wobei der Servomotor bzw. die Vorschubwalzen pro Vorschubintervall mit einer Steuerung gemäss einem vorgegebenen Soll-Bewegungs- und Stillstandsprofil gesteuert werden können.
- Werkzeugmaschine nach einem der Ansprüche 8 bis 12, wobei die Werkzeugmaschine eine Stanzpresse ist und wobei das Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen mit dem Bewegungsprofil des Pressenstössels synchronisierbar ist.
- Werkzeugmaschine nach Anspruch 13, wobei die Synchronisation als relative Synchronisation durchführbar ist, so dass im Soll-Bewegungs- und Stillstandsprofil des Servomotors bzw. der Vorschubwalzen beliebig gestartet und gestoppt werden kann.
- Werkzeugmaschine nach einem der Ansprüche 8 bis 14, wobei die Werkzeugmaschine derartig ausgestaltet ist, dass nach dem Ausfahren des oder der Pilotstifte aus den Pilotöffnungen des Materialbandes und während dem Aufheben der Reduzierung des Haltemoments der Vorschubwalzen die Vorschubwalzen auf eine allfällige Drehbewegung überwacht werden können und bei Überschreiten eines bestimmten max. zulässigen Verdrehwinkels die Presse automatisch gestoppt werden kann, insbesondere unter einer Visualisierung des festgestellten Verdrehwinkels über die Pressensteuerung.
- Werkzeugmaschine nach Anspruch 15, wobei die Werkzeugmaschine derartig ausgestaltet ist, dass die Überwachung mit dem Start der Verschiebung des folgenden Vorschubintervalls beginnt und bei Beendigung der Reduzierung oder Aufhebung des Haltemoments endet.
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| SI202030508T SI4200092T1 (sl) | 2020-09-25 | 2020-09-25 | Postopek za dovajanje traka materiala v obdelovalno cono obdelovalnega stroja |
| PL20781479.9T PL4200092T3 (pl) | 2020-09-25 | 2020-09-25 | Sposób doprowadzania taśmy materiału do strefy obróbki obrabiarki |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/EP2020/076989 WO2021058792A2 (de) | 2020-09-25 | 2020-09-25 | Verfahren zum zuführen eines materialbandes zur bearbeitungszone einer werkzeugmaschine |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP4200092A2 EP4200092A2 (de) | 2023-06-28 |
| EP4200092B1 true EP4200092B1 (de) | 2024-08-14 |
Family
ID=72670704
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP20781479.9A Active EP4200092B1 (de) | 2020-09-25 | 2020-09-25 | Verfahren zum zuführen eines materialbandes zur bearbeitungszone einer werkzeugmaschine |
Country Status (7)
| Country | Link |
|---|---|
| US (1) | US20230356424A1 (de) |
| EP (1) | EP4200092B1 (de) |
| JP (1) | JP7774618B2 (de) |
| ES (1) | ES2991176T3 (de) |
| PL (1) | PL4200092T3 (de) |
| SI (1) | SI4200092T1 (de) |
| WO (1) | WO2021058792A2 (de) |
Family Cites Families (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE1126830B (de) * | 1958-07-15 | 1962-04-05 | Kieserling & Albrecht | Vorrichtung zum schrittweisen Zu- und Abfuehren von Blechbaendern bzw. -profilen an Pressen, Stanzen oder dergleichen Bearbeitungsmaschinen |
| JPS62137130A (ja) * | 1985-12-12 | 1987-06-20 | Orii:Kk | プレス加工用材料の送り装置におけるリリ−シング制御装置 |
| US5992722A (en) * | 1996-11-26 | 1999-11-30 | The Minster Machine Company | Zero force roll release for high speed press feed units |
| US7287678B2 (en) * | 2001-11-16 | 2007-10-30 | Vamco International Inc. | Method and apparatus for determining and setting material release mechanism timing for a material feed mechanism |
| JP4429352B2 (ja) * | 2007-10-31 | 2010-03-10 | 株式会社三共製作所 | 板材送り装置 |
| CN110479895B (zh) * | 2019-09-27 | 2020-11-27 | 扬州铭诚鑫智能科技有限公司 | 一种nck高速伺服送料机及其控制方法 |
-
2020
- 2020-09-25 PL PL20781479.9T patent/PL4200092T3/pl unknown
- 2020-09-25 ES ES20781479T patent/ES2991176T3/es active Active
- 2020-09-25 US US18/246,453 patent/US20230356424A1/en active Pending
- 2020-09-25 EP EP20781479.9A patent/EP4200092B1/de active Active
- 2020-09-25 SI SI202030508T patent/SI4200092T1/sl unknown
- 2020-09-25 JP JP2023518947A patent/JP7774618B2/ja active Active
- 2020-09-25 WO PCT/EP2020/076989 patent/WO2021058792A2/de not_active Ceased
Also Published As
| Publication number | Publication date |
|---|---|
| WO2021058792A3 (de) | 2021-07-08 |
| ES2991176T3 (es) | 2024-12-02 |
| EP4200092A2 (de) | 2023-06-28 |
| US20230356424A1 (en) | 2023-11-09 |
| PL4200092T3 (pl) | 2025-01-13 |
| WO2021058792A2 (de) | 2021-04-01 |
| JP7774618B2 (ja) | 2025-11-21 |
| JP2023549304A (ja) | 2023-11-24 |
| SI4200092T1 (sl) | 2025-01-31 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP2756893B1 (de) | Materialbearbeitungsvorrichtung, insbesondere eine Umformmaschine | |
| EP0485542B2 (de) | Verfahren und vorrichtung zum einrichten eines dreischneiders | |
| DE69313639T2 (de) | Verstellbarer drahtschneid- und entmantelungsapparat | |
| DE2728647A1 (de) | Formteilpresse | |
| EP0611612A1 (de) | Drückwalzmschine | |
| DE102008053591B4 (de) | Steuerungsverfahren für Stanzautomat | |
| DE2335966A1 (de) | Verfahren und vorrichtung zum schlitzen von metallstreifen | |
| EP0266709A2 (de) | Kupplungseinrichtung an einer Spritzgiessmaschine zum Ankuppeln der Schneckenwelle | |
| DE68919343T2 (de) | Verfahren und Vorrichtung zum Nachladen eines Pilgerwalzwerkes. | |
| DE3524212A1 (de) | Verfahren und einrichtung zur sicherheitsueberwachung einer numerisch gesteuerten werkzeugmaschine | |
| EP4200092A2 (de) | Verfahren zum zuführen eines materialbandes zur bearbeitungszone einer werkzeugmaschine | |
| EP1657008B1 (de) | Vorrichtung zum Zuführen eines bandförmigen Halbzeugmaterials zu einer Presse und Verfahren zum Einstellen der Banddicke einer Vorschubvorrichtung | |
| DE2733013C2 (de) | Verfahren und Einrichtung zum Signalisieren und Aussortieren von falsch gewalzten Werkstücken bei Gewindewalzmaschinen | |
| DE2656067C3 (de) | Maschine zum aufeinanderfolgenden Abstechen von Dichtungsringen von einer schlauchförmigen, gummiartigen Hülse | |
| DE4203952A1 (de) | Vorrichtung und verfahren zum positionieren der fuehler bei einer bahnlaufregeleinrichtung | |
| EP3956084B1 (de) | Setzkopf, blechpresse oder setzgerät mit diesem setzkopf sowie ein fügeverfahren eines fügeelements mit dem setzkopf | |
| EP3790678B1 (de) | Verfahren mit einer fertigungseinrichtung zum umformen von blech | |
| EP2384833B1 (de) | Niederhalterregelung bei der Herstellung von Dosenkörpern | |
| DD160759A5 (de) | Verschliesseinrichtung | |
| DE102007024588A1 (de) | Textilmaschine mit einer Abhebeeinrichtung und Verfahren zum Betreiben einer Textilmaschine | |
| EP1345715B1 (de) | Schmiedepresse mit stellvorrichtung auf matrizenseite | |
| DE102017113382B3 (de) | Gewindewalzverfahren und Gewindewalzvorrichtung zur Herstellung eines Gewindes | |
| EP0186072A2 (de) | Trennmaschine für kreisbogenförmige Profilstücke oder Profilringe | |
| DE69404792T2 (de) | Maschine zum Anspitzen von Stäben | |
| DE69005575T2 (de) | Befestigung eines Werkzeugs zum Ausstossen oder Abtrennen von Teilen oder eines ähnlichen Werkzeugs. |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: UNKNOWN |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE INTERNATIONAL PUBLICATION HAS BEEN MADE |
|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20230324 |
|
| AK | Designated contracting states |
Kind code of ref document: A2 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| DAV | Request for validation of the european patent (deleted) | ||
| DAX | Request for extension of the european patent (deleted) | ||
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20240315 |
|
| P01 | Opt-out of the competence of the unified patent court (upc) registered |
Effective date: 20240430 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 502020008887 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: GERMAN |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 2991176 Country of ref document: ES Kind code of ref document: T3 Effective date: 20241202 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20240814 Ref country code: SK Ref legal event code: T3 Ref document number: E 45293 Country of ref document: SK |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241114 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241115 Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241216 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241214 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241114 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241114 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241216 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241114 Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241214 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241115 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 502020008887 Country of ref document: DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20240925 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20240930 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20240930 |
|
| 26N | No opposition filed |
Effective date: 20250515 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20240925 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20240814 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: U11 Free format text: ST27 STATUS EVENT CODE: U-0-0-U10-U11 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20251001 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250919 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20250923 Year of fee payment: 6 Ref country code: PL Payment date: 20250911 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20250919 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20250922 Year of fee payment: 6 Ref country code: AT Payment date: 20250919 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: CZ Payment date: 20250916 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: SK Payment date: 20250916 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: SI Payment date: 20250911 Year of fee payment: 6 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R082 Ref document number: 502020008887 Country of ref document: DE Representative=s name: HOFFMANN EITLE PATENT- UND RECHTSANWAELTE PART, DE |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: CH Payment date: 20251001 Year of fee payment: 6 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20200925 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20251030 Year of fee payment: 6 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20200925 |