CN101818480B - Box girder transfer platform and girder transferring and girder loading working procedures thereof - Google Patents
Box girder transfer platform and girder transferring and girder loading working procedures thereof Download PDFInfo
- Publication number
- CN101818480B CN101818480B CN 201010146619 CN201010146619A CN101818480B CN 101818480 B CN101818480 B CN 101818480B CN 201010146619 CN201010146619 CN 201010146619 CN 201010146619 A CN201010146619 A CN 201010146619A CN 101818480 B CN101818480 B CN 101818480B
- Authority
- CN
- China
- Prior art keywords
- telescopic arm
- support
- assembly
- trolley
- girder
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images


Landscapes
- Bridges Or Land Bridges (AREA)
Abstract
本发明涉及一种箱梁转运平台及其移梁和装梁工序,其中,该平台包括驮梁小车、伸缩臂、横梁总成、门型架、驱动系统、液压系统和电气系统,驮梁小车安装在伸缩臂上,伸缩臂由与预埋基础连接的门型架以及在其上的横梁总成支撑,驱动系统的驱动装置布置在伸缩臂后端,驱动系统的导向轮布置在伸缩臂前后两端面上,液压系统的泵站位于门型架的主梁上,电气系统的主柜布置在门型架的主梁上,该转运平台可用于箱梁的转运操作,可从运梁车上取梁后将箱梁移到桥面一侧,运架一体架桥机运行到转运平台旁边后,从侧面为运架一体架桥机喂梁,实现了运梁和架桥平行施工,大大提高了运架一体架桥机的架梁速度。
The invention relates to a box girder transfer platform and its beam moving and beam loading procedures, wherein the platform includes a beam trolley, a telescopic arm, a beam assembly, a portal frame, a drive system, a hydraulic system and an electrical system, and the beam trolley is installed On the telescopic arm, the telescopic arm is supported by the portal frame connected to the embedded foundation and the beam assembly on it. The driving device of the drive system is arranged at the rear end of the telescopic arm, and the guide wheels of the drive system are arranged at the front and rear of the telescopic arm. On the end face, the pump station of the hydraulic system is located on the main beam of the portal frame, and the main cabinet of the electrical system is arranged on the main beam of the portal frame. After the girder, the box girder is moved to the side of the bridge deck, and the integrated bridge-erecting machine runs to the side of the transfer platform, and feeds the beam to the integrated bridge-erecting machine from the side, realizing the parallel construction of beam transport and bridge erection, which greatly improves The girder erecting speed of the integrated bridge erecting machine.
Description
技术领域 technical field
本发明涉及一种箱梁转运平台及其移梁和装梁工序。The invention relates to a box girder transfer platform and its beam moving and beam loading procedures.
背景技术 Background technique
随着我国基础建设的进一步加强和发展,各种基础设施的建设正在进入一个快速、稳健的发展阶段,铁路“十一五”规划表明,中国铁路已进入跨越式发展阶段,尤其是经济危机以来,我国加大对铁路、公路等基础设施的投入,铁路建设施工达到前所未有的高峰期。随着我国铁路建设迈进持续快速发展阶段,在铁路建设施工方面首先要解决的一个关键问题是如何以较低的施工成本,较高的施工效率,进行铁路建设施工,以满足日益增长的需求,从而跟上经济发展的步伐。With the further strengthening and development of my country's infrastructure, the construction of various infrastructures is entering a rapid and steady development stage. The "Eleventh Five-Year Plan" of railways shows that China's railways have entered a stage of leapfrog development, especially since the economic crisis. my country has increased investment in infrastructure such as railways and highways, and railway construction has reached an unprecedented peak. As my country's railway construction enters a stage of continuous and rapid development, a key problem to be solved in the aspect of railway construction is how to carry out railway construction with low construction cost and high construction efficiency to meet the growing demand. So as to keep up with the pace of economic development.
目前,在铁路建设施工过程中,为了不占用土地、确保铁路运行的安全,铁路上的高架部分所占的比重越来越大,而在高架线路中,大型混凝土箱梁作为重量支承件成为了高架路线上的重要部件,而由于这种大型混凝土箱梁的重量大,在运输和建设高架铁路时非常困难。目前,对这种箱梁通常采用两种施工方式:一是先采用运梁车实现箱梁的运输,然后与其配套的架桥机直接从运梁车上取梁并在施工现场架桥,这种工法称为运架分离式,该工法可实现平行作业,施工效率高,但施工成本比较大;而另一种方式则采用运架一体架桥机直接从预制梁场取梁,并直接运输到施工现场架桥,从而实现顺序作业,这种方式施工成本小,但施工效率很低。At present, in the process of railway construction, in order not to occupy land and ensure the safety of railway operation, the proportion of elevated parts on railways is increasing. In elevated lines, large concrete box girders are used as weight supports. Important components on elevated routes, and due to the heavy weight of such large concrete box girders, it is very difficult to transport and construct elevated railways. At present, two construction methods are usually used for this kind of box girder: one is to use the beam transporter to realize the transport of the box girder, and then the supporting bridge erecting machine directly takes the beam from the beam transporter and erects the bridge at the construction site. The first construction method is called the separated type of transport frame, which can realize parallel operation and high construction efficiency, but the construction cost is relatively high; while the other method uses the integrated bridge erecting machine to directly take the beams from the prefabricated beam yard and transport them directly Go to the construction site to build bridges to achieve sequential operations. This method has low construction cost, but the construction efficiency is very low.
由此,为了提高运架一体架桥机的架桥效率,必需采用运梁车为运架一体架桥机运梁,这样才能大大节约时间,提高效率,但因运梁车和运架一体架桥机同在桥面的一条通道上,运梁车不能直接从侧面为运架一体架桥机喂梁。而解决这一问题的方法,是在制梁场和架桥现场中间设置一个转运平台,通过这个转运平台将箱梁从运梁车上取到并转运到桥面侧面,再通过转运平台从侧面为运架一体架桥机喂梁,实现运梁车和运架一体架桥机的有效结合,从而达到平行作业,提高效率。Therefore, in order to improve the bridge erecting efficiency of the integrated bridge erecting machine, it is necessary to use a beam transport vehicle to transport the beams for the integrated bridge erecting machine, which can greatly save time and improve efficiency, but because the beam transport vehicle and the integrated frame transport The bridge machine is on the same passage on the bridge deck, and the beam transport vehicle cannot directly feed the beam for the integrated bridge erecting machine from the side. The way to solve this problem is to set up a transfer platform between the beam making yard and the bridge erection site, through which the box girders are taken from the beam truck and transferred to the side of the bridge deck, and then transported from the side through the transfer platform. The integrated bridge erecting machine feeds the beam to realize the effective combination of the beam transport vehicle and the integrated bridge erecting machine, so as to achieve parallel operation and improve efficiency.
而且在预制梁场给运架一体架桥机装梁时,由于不能直接将提梁机上的梁片从运架一体架桥机后面送入来实现喂梁。于是在施工现场的预制梁场的桥面外侧处通常需要设置一个专用的旋转平台,通过该旋转平台进行装梁操作,但现有的装梁工序复杂,不能适应不同规格梁片的装取。And when the prefabricated girder yard loads the girder for the integrated bridge erecting machine with transport and frame, it is impossible to directly feed the beams on the beam lifting machine from the back of the integrated bridge erection machine with transport and frame. Therefore, it is usually necessary to set up a special rotating platform on the outside of the bridge deck of the prefabricated beam yard at the construction site, through which the beam loading operation is performed, but the existing beam loading process is complicated and cannot be adapted to the loading and unloading of beams of different specifications.
为此,需要提供一套能够完成运梁车和运架一体架桥机有效结合,实现从预制梁场装梁、运梁到架梁整个架桥过程,而且经济实用、施工效率高的箱梁转运平台及其移梁工序和变跨工序。Therefore, it is necessary to provide a set of economical, practical and efficient box girders that can complete the effective combination of the beam transport vehicle and the integrated bridge erecting machine, and realize the entire bridge erection process from the prefabricated beam yard, beam transport to beam erection. Transfer platform and its beam moving process and span changing process.
发明内容 Contents of the invention
本发明的目的是针对上述现状,提供一种能够完成运梁车和运架一体架桥机有效结合,实现从预制梁场取梁、运梁、喂梁、架梁等整个架桥过程,而且经济实用、施工效率高的箱梁转运平台及其移梁、变跨和装梁工序。The object of the present invention is to aim at the above-mentioned present situation, provide a kind of can complete the effective combination of beam transport vehicle and frame transport integrated bridge erecting machine, realize the whole bridge erecting process such as taking beam from prefabricated beam yard, transporting beam, feeding beam, erecting beam, and An economical and practical box girder transfer platform with high construction efficiency and its beam moving, span changing and beam loading procedures.
为实现上述目的,本发明公开了一种箱梁转运平台,其中,该平台包括驮梁小车、伸缩臂、横梁总成、门型架、驱动系统、液压系统和电气系统,驮梁小车安装在伸缩臂上,伸缩臂由与预埋基础连接的门型架以及在其上的横梁总成支撑,驱动系统的驱动装置布置在伸缩臂后端,驱动系统的导向轮布置在伸缩臂前后两端面上,液压系统的泵站位于门型架的主梁上,电气系统的主柜布置在门型架的主梁上。In order to achieve the above object, the present invention discloses a box girder transfer platform, wherein the platform includes a carrying beam trolley, a telescopic arm, a beam assembly, a portal frame, a drive system, a hydraulic system and an electrical system, and the carrying beam trolley is installed on On the telescopic arm, the telescopic arm is supported by the portal frame connected to the embedded foundation and the beam assembly on it, the driving device of the drive system is arranged at the rear end of the telescopic arm, and the guide wheels of the drive system are arranged on the front and rear ends of the telescopic arm Above, the pump station of the hydraulic system is located on the main beam of the portal frame, and the main cabinet of the electrical system is arranged on the main beam of the portal frame.
其中,驮梁小车由钢垫、台车架、可调链条安装座、移运器、拉杆、插销固定支座和滚轮装置组成;其中:钢垫固定于台车架上面,台车架一端通过拉杆与销固定支座连接,台车架另一端安装可调链条安装座,台车架底面安装移运器;其中,可调链条安装座由链条座、螺杆、链条挡板、链销轴、链条底座和加强筋板组成;其中,链条座安装有螺杆、链销轴和链条挡板,螺杆与焊接在台车架上的螺母之间相互旋合,链销轴与驱动系统的链条连接,链条底座支撑链条座在其上移动。Among them, the beam trolley is composed of a steel pad, a trolley frame, an adjustable chain mounting seat, a transfer device, a pull rod, a bolt fixing support and a roller device; wherein: the steel pad is fixed on the trolley frame, and one end of the trolley frame passes through The pull rod is connected with the pin fixed support, the other end of the trolley frame is installed with an adjustable chain mounting seat, and the bottom of the trolley frame is equipped with a transfer device; wherein, the adjustable chain mounting seat is composed of a chain seat, a screw rod, a chain baffle, a chain pin shaft, The chain base is composed of a reinforcing rib plate; among them, the chain base is equipped with a screw rod, a chain pin shaft and a chain baffle, the screw rod and the nut welded on the frame of the trolley are screwed together, and the chain pin shaft is connected with the chain of the drive system. The chain base supports the chain base to move thereon.
其中,伸缩臂由螺杆组件、端铰支座、端垫梁组件、长臂、支腿总成、扁担梁和挡块组成;其中,长臂由箱形结构梁和结构梁中的插销套筒组成,螺杆组件一端通过端铰支座连接端垫梁组件,另一端可与长臂上的螺纹套筒旋合;其中,支腿总成由螺杆组件、挡板和铰座组成,螺杆组件的球头安装在通过螺栓连接的挡板与铰座之间,扁担梁由支撑梁和设置于支撑梁内与螺杆组件相互旋合的螺旋套筒组成,支腿总成一端连接长臂上,一端连接扁担梁。Among them, the telescopic arm is composed of screw rod assembly, end hinge support, end pad beam assembly, long arm, outrigger assembly, pole beam and stopper; wherein, the long arm is composed of a box-shaped structural beam and a bolt sleeve in the structural beam One end of the screw assembly is connected to the end pad beam assembly through the end hinge support, and the other end can be screwed with the threaded sleeve on the long arm; wherein, the outrigger assembly is composed of a screw assembly, a baffle and a hinge seat, and the screw assembly The ball head is installed between the baffle plate and the hinge seat connected by bolts. The shoulder pole beam is composed of a support beam and a spiral sleeve arranged in the support beam and screwed with the screw assembly. One end of the outrigger assembly is connected to the long arm, and the other end is Connect pole beams.
其中,横梁总成由上反扣支座、移运器总成、横梁、插销支座、变跨油缸总成、插销、导向支座总成、下反扣支座和下反扣螺杆组成;其中,上反扣支座、移运器总成、插销支座、插销和导向支座总成位于横梁上表面,变跨油缸总成位于横梁侧面,下反扣支座和下反扣螺杆位于横梁下表面。Among them, the crossbeam assembly is composed of an upper reverse buckle support, a transfer device assembly, a beam, a bolt support, a variable span oil cylinder assembly, a bolt, a guide support assembly, a lower reverse buckle support and a lower reverse buckle screw; Among them, the upper reverse buckle support, transfer device assembly, latch support, latch and guide support assembly are located on the upper surface of the beam, the variable-span oil cylinder assembly is located on the side of the beam, and the lower reverse buckle support and lower reverse buckle screw are located on the The lower surface of the beam.
其中,还包括伸缩控制装置,伸缩控制装置由驮梁小车上的销固定支座和滚轮装置、通过法兰板固定的插销、插销支座、移运器总成以及伸缩臂上的插销套筒组成,在伸缩控制装置控制下实现伸缩臂带载伸缩。Among them, the telescopic control device is also included, and the telescopic control device is composed of a pin-fixed support and a roller device on the beam trolley, a bolt fixed by a flange plate, a bolt support, a transfer device assembly, and a bolt sleeve on the telescopic arm. Composition, under the control of the telescopic control device, the telescopic arm can be stretched under load.
其中,用一套驱动机构在伸缩控制装置控制下能驱动伸缩臂的伸缩和驮梁小车的行走;其中驱动机构由驱动装置、左导向轮、右导向轮和滚子链组成,滚子链一端通过驮梁小车上的可调链条安装座与驮梁小车的台车架连接,经过驱动装置、安装在伸缩臂上的右导向轮、左导向轮,最后通过驮梁小车上另一端的可调链条安装座与驮梁小车另一端的台车架连接。Among them, a set of driving mechanism can drive the expansion and contraction of the telescopic arm and the walking of the beam trolley under the control of the telescopic control device; the driving mechanism is composed of a driving device, a left guide wheel, a right guide wheel and a roller chain. One end of the roller chain The adjustable chain mounting seat on the pack beam trolley is connected to the frame of the pack beam trolley, through the driving device, the right guide wheel and the left guide wheel installed on the telescopic arm, and finally through the adjustable chain on the other end of the pack beam trolley. The chain mounting seat is connected with the platform frame at the other end of the pack beam trolley.
其中,将运梁车上的箱梁取下伸缩到桥面外则,运架一体架桥机运行到转运平台旁边后,从侧面为运架一体架桥机喂梁。Among them, the box girder on the beam transport vehicle is removed and stretched to the outside of the bridge deck, and the integrated bridge erecting machine with transport and frame runs to the side of the transfer platform, and then feeds the beam for the integrated bridge erection machine with transport and frame from the side.
其中,该工序包括以下步骤:Wherein, the process includes the following steps:
a、伸缩臂伸缩到桥面外侧,让开桥面通道;运梁车运载箱梁至转运平台对位;a. The telescopic arm stretches to the outside of the bridge deck to get out of the way of the bridge deck; the girder truck carries the box girder to the transfer platform for alignment;
b、伸缩臂伸入至桥面,安装螺旋支承;b. The telescopic arm is extended to the bridge deck, and the screw support is installed;
c、驮梁小车行走至箱梁下方对位,运梁车落梁,箱梁落放在驮梁小车支座上,运梁车卸载;c. The carrying beam trolley walks to the position below the box girder, the beam transporting vehicle drops the beam, the box girder falls on the support of the carrying beam trolley, and the beam transporting vehicle unloads;
d、驮梁小车驮运箱梁到桥面外侧;d. The beam trolley carries the box girder to the outside of the bridge deck;
e、撤除螺旋支承,伸缩臂伸缩到桥面外侧,运梁车返回梁场取梁;e. Remove the screw support, stretch the telescopic arm to the outside of the bridge deck, and return the beam truck to the beam yard to take the beam;
f、运架一体架桥机空载运行至转运平台对位;f. The transport-frame integrated bridge erecting machine runs without load to the alignment of the transfer platform;
g、伸缩臂伸出至桥面,安装螺旋支承;g. The telescopic arm is stretched out to the bridge deck, and the screw support is installed;
h、驮梁小车驮运箱梁至运架一体架桥机下方;h. The beam trolley carries the box girder to the bottom of the integrated bridge erecting machine;
i、运架一体架桥机吊起箱梁;i. The box girder is lifted by the integrated bridge erecting machine;
j、驮梁小车空载运行到桥面外侧,撤除螺旋支承,伸缩臂移到桥面外侧,让开桥面通道,运架一体架桥机前行架梁。j. The beam trolley runs to the outside of the bridge deck with no load, removes the screw support, moves the telescopic arm to the outside of the bridge deck, clears the bridge deck passage, and transports the integrated bridge erecting machine to erect the girder.
其装梁工序包括以下步骤:Its beam installation process includes the following steps:
a、提梁机从预制梁场提取梁片,并放到转运平台上;a. The beam lifting machine extracts the beam pieces from the prefabricated beam field and puts them on the transfer platform;
b、运架一体架桥机空载运行至转运平台对位;b. The integrated bridge erecting machine runs without load to the alignment of the transfer platform;
c、将转运平台伸缩臂伸出至桥面,安装螺旋支承;c. Extend the telescopic arm of the transfer platform to the bridge deck and install the screw support;
d、驮梁小车驮运箱梁横移至运架一体架桥机下方;d. The beam trolley carries the box girder and moves to the lower part of the integrated bridge erecting machine;
e、运架一体架桥机吊起箱梁;e. The box girder is lifted by the integrated bridge erecting machine;
f、驮梁小车空载运行到桥面外侧,撤除螺旋支承,伸缩臂移到桥面外侧,让开桥面通道,运架一体架桥机前行架梁。f. The beam trolley runs to the outside of the bridge deck with no load, removes the screw support, moves the telescopic arm to the outside of the bridge deck, clears the bridge deck passage, and transports the integrated bridge erecting machine to erect the girder.
其伸缩臂伸缩到桥面外侧或提梁机从预制梁场提取梁片时,转运平台根据待转运箱梁的规格,已完成变跨工序,该变跨工序包括以下步骤:When the telescopic arm stretches to the outside of the bridge deck or the girder lifting machine picks up the girder pieces from the prefabricated girder field, the transfer platform has completed the span-changing process according to the specifications of the box girder to be transferred. The span-changing process includes the following steps:
a、将伸缩臂和驮梁小车停止在重心位于门架中心;a. Stop the telescopic arm and the beam trolley when the center of gravity is at the center of the mast;
b、将下反扣的四个顶紧丝杆松开;b. Loosen the four top tightening screw rods of the bottom buckle;
c、不断更换油缸座的位置,直到变跨作业完成。c. Change the position of the oil cylinder seat continuously until the span change operation is completed.
通过上述结构,本发明已在广珠城际轨道交通建设中成功使用,且证实具有以下优点:Through the above structure, the present invention has been successfully used in the construction of Guangzhou-Zhuhai intercity rail transit, and has been proved to have the following advantages:
1、首次采用侧面移梁和喂梁方式1. For the first time, the method of side beam moving and beam feeding is adopted
用运梁车为运架一体架桥机运梁突破了运架一体架桥机的取梁工法,将运梁车上的箱梁从侧面喂给运架一体架桥机在国内外无此史例。该平台能从运梁车上取梁后将箱梁移到桥面一侧,运架一体架桥机运行到转运平台旁边后,从侧面为运架一体架桥机喂梁,实现了运梁和架桥平行施工。而且,在运架一体架桥机到达预制梁场前,提梁机就可以从预制梁场提取梁片,并放到转运平台上,准备装梁,进一步节省了时间,提高了效率。Using the beam truck to transport the girder for the integrated bridge erecting machine breaks through the beam taking method of the integrated bridge erecting machine, and feeds the box girder on the beam transport vehicle to the integrated bridge erecting machine from the side, which has no such history at home and abroad example. The platform can move the box girder to one side of the bridge deck after taking the girder from the girder truck, and after the integrated bridge erecting machine runs to the side of the transfer platform, it can feed the beam to the integrated bridge erecting machine from the side, realizing the beam transportation Parallel to bridge construction. Moreover, before the integrated bridge erecting machine arrives at the prefabricated girder field, the girder lifting machine can extract the girder pieces from the prefabricated girder field and put them on the transfer platform to prepare for girder loading, which further saves time and improves efficiency.
2、不影响既有交通,无需拆迁,环保性能好;2. It does not affect the existing traffic, does not need to be demolished, and has good environmental protection performance;
3、移梁安全可靠、操作灵活方便,平台成本低、施工效率高,能达到每片梁1.5小时的理论转运效率。3. Beam moving is safe and reliable, flexible and convenient to operate, low platform cost, high construction efficiency, and can reach the theoretical transfer efficiency of 1.5 hours per beam.
附图说明 Description of drawings
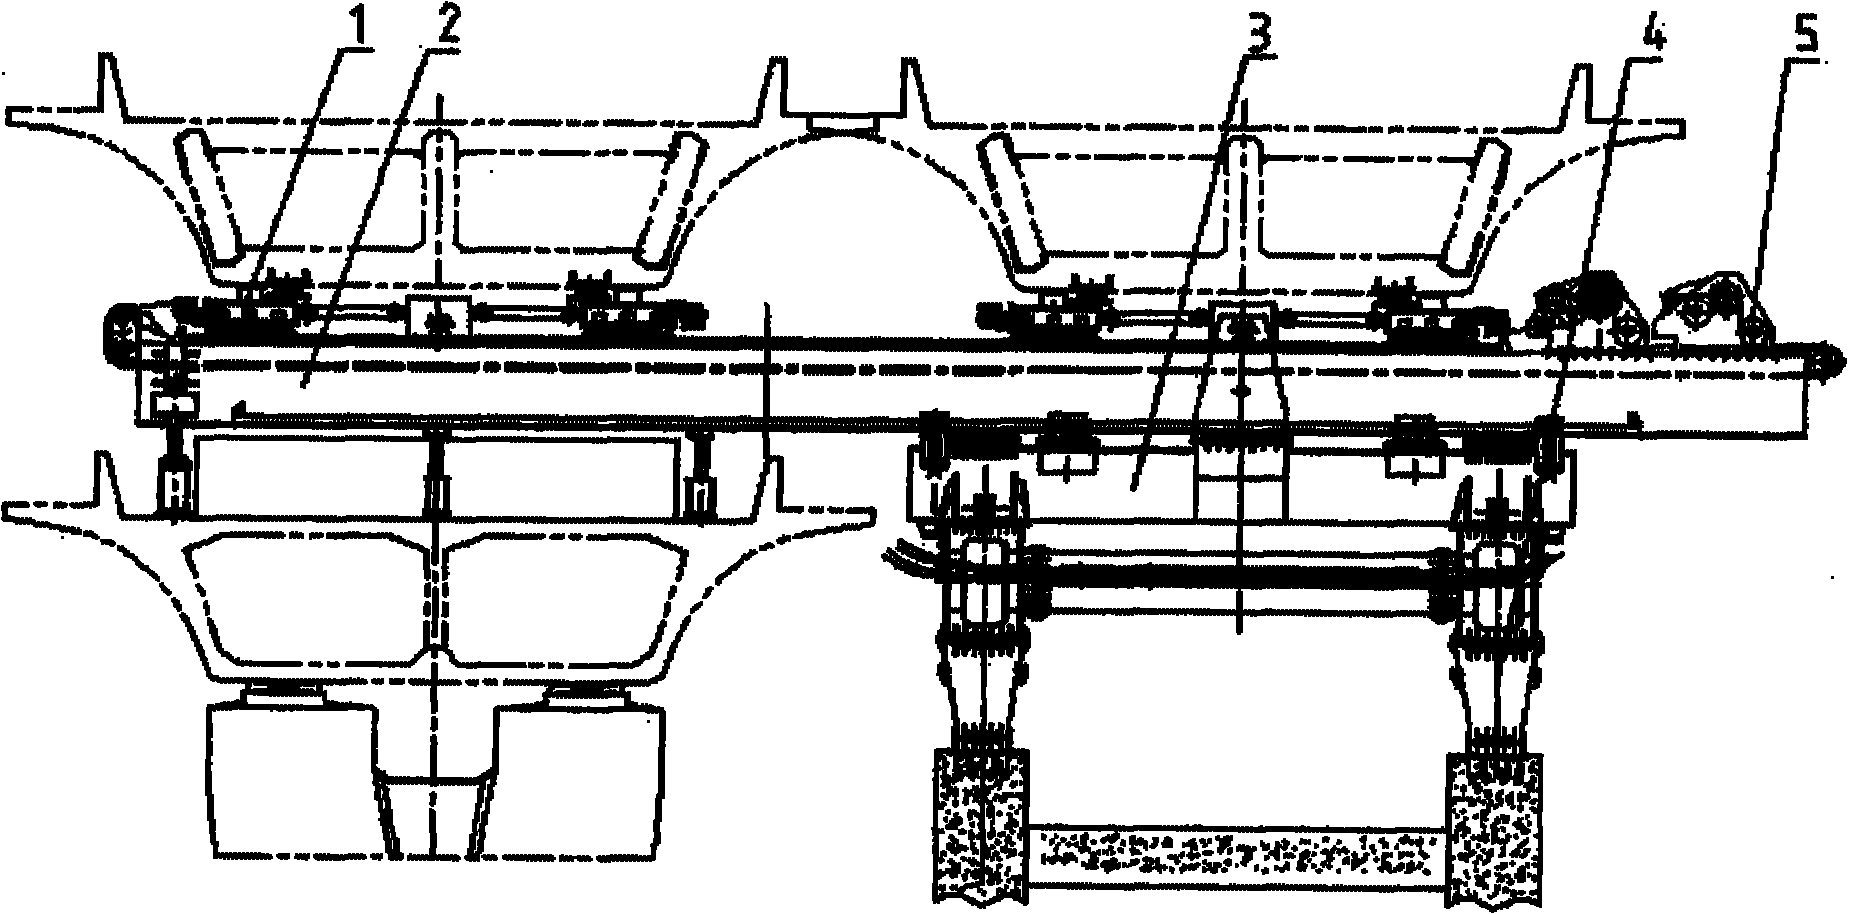
图1A为本发明转运平台结构的主视图。Fig. 1A is a front view of the structure of the transport platform of the present invention.
图1B为本发明转运平台结构的左视图。Fig. 1B is a left view of the transport platform structure of the present invention.
图2为驮梁小车结构的主视图。Fig. 2 is the front view of the structure of the pack beam trolley.
图3为伸缩臂结构的主视图。Fig. 3 is a front view of the telescopic arm structure.
图4A为横梁总成结构的主视图。Fig. 4A is a front view of the beam assembly structure.
图4B为A-A向的横梁总成结构的侧视图。Fig. 4B is a side view of the beam assembly structure in the A-A direction.
图4C为B-B向的横梁总成结构的侧视图。Fig. 4C is a side view of the beam assembly structure in the B-B direction.
图4D为C-C向的横梁总成结构的侧视图。Fig. 4D is a side view of the beam assembly structure in the C-C direction.
图5A为门型架结构的主视图。Fig. 5A is a front view of the gantry structure.
图5B为门型架结构的左视图。Fig. 5B is a left side view of the gantry structure.
图6A为驱动系统结构的主视图。Fig. 6A is a front view of the drive system structure.
图6B为驱动系统结构的左视图。Fig. 6B is a left view of the drive system structure.
图7为伸缩控制装置结构的主视图。Fig. 7 is a front view of the structure of the telescoping control device.
图8为本发明移梁工序的示意图。Fig. 8 is a schematic diagram of the beam moving process of the present invention.
图9A为可调链条安装座的正视图。Figure 9A is a front view of an adjustable chain mount.
图9B为图9A所示可调链条安装座沿A-A的侧视图。Fig. 9B is a side view along A-A of the adjustable chain mount shown in Fig. 9A.
图9C为图9A所示可调链条安装座沿B-B的俯视图。Fig. 9C is a top view along B-B of the adjustable chain mounting seat shown in Fig. 9A.
图10为本发明支腿总成的示意图。Fig. 10 is a schematic diagram of the outrigger assembly of the present invention.
图11A为本发明移运器总成的正视图。Figure 11A is a front view of the transporter assembly of the present invention.
图11B为本发明移运器总成的侧视图。Figure 1 IB is a side view of the transporter assembly of the present invention.
图12为本发明变跨油缸总成的示意图。Fig. 12 is a schematic diagram of the span variable cylinder assembly of the present invention.
具体实施方式 Detailed ways
参考图1,为本发明的箱梁转运平台,该转运平台主要由驮梁小车1、伸缩臂2、横梁总成3、门型架4和驱动系统5、液压系统6、电气系统7组成。其中液压系统6可由泵站及相关执行元件等组成,在用于完成不同跨度箱梁移梁要求时,可根据需要选择符合要求的泵站和满足要求的执行元件;而电气系统7可由变频器、控制箱、电气柜等组成,主要实现过电流、过电压、欠电压、漏电等保护与所有动作(如联动、紧急停止等)的集中控制,由于液压系统6和电气系统7均为本领域所共知的技术,因此不再进行详细描述。驮梁小车1安装在伸缩臂2上,伸缩臂2由与预埋基础连接的门型架4以及在其上的横梁总成3支撑,驱动系统5的驱动装置布置在伸缩臂2后端,驱动系统5的导向轮布置在伸缩臂2前后两端面上,液压系统6的泵站位于门型架4的主梁上,电气系统7的主柜布置在门型架4的主梁上。Referring to Fig. 1, it is a box girder transfer platform of the present invention, which is mainly composed of a beam trolley 1, a
现参考图2,显示了本发明的驮梁小车1,该驮梁小车1主要由钢垫11、台车架12、可调链条安装座13、移运器14、拉杆15、销固定支座16和滚轮装置17组成。其中,钢垫11固定于台车架12上面,用来支撑箱梁,在箱梁运输时,箱梁放在钢垫11上;台车架12可通过链条驱动来实现左右移动,从而实现箱梁的移动;台车架12一端通过拉杆15与销固定支座16连接,连接方式可为例如销或螺栓连接的方式,台车架12另一端安装可调链条安装座13;台车架12底面安装有移运器14,移运器14可通过滚子实现将其上面的台车架12与其下面的伸缩臂2变为滚动;销固定支座16通过与销轴配合,来实现驮梁小车1移动或伸缩臂2伸缩;可调链条安装座13,用于连接驱动驮梁小车1或伸缩臂2运动的链条,该链条优选为滚子链。Now referring to Fig. 2, it shows the carrying beam dolly 1 of the present invention. 16 and
为了进一步清楚的描述可调链条安装座13,请参考图9,显示了可调链条安装座13的正视图、侧视图和俯视图。该可调链条安装座13由螺杆61、链条座62、链条挡板63、链销轴64、链条底座65和加强筋板66组成,其中,链条座62上安装有螺杆61、链条挡板63和链销轴64,链条座62可移动的支撑于链条底座65上,螺杆61与焊接在台车架上的螺母之间相互旋合,链销轴64与驱动系统5的链条连接,链条底座65支撑链条座62在其上移动。通过安装在链条座上的链销轴带动链条的运动,实现链条连接的距离在一定范围内可变,从而实现可调。In order to further describe the
参考图3,伸缩臂2主要由螺杆组件21、端铰支座22、端垫梁组件23、长臂24、支腿总成25、扁担梁26和挡块27组成。其中,长臂24主要由箱形结构梁和结构梁中的插销套筒组成;螺杆组件21一端通过端铰支座22连接端垫梁组件23,另一端可与长臂24上的螺纹套筒旋合;支腿总成25一端连接长臂24,一端连接扁担梁26;挡块27由两块板和筋板焊接而成,伸缩臂2在伸缩时,该档块27主要用于限位,可根据需要进行设置。当伸缩臂2伸到桥面后,用螺杆组件21通过与长臂24上的螺纹套筒的相对旋合运动,在端铰支座22和端垫梁组件23的支撑下,实现对伸缩臂2的支撑。Referring to FIG. 3 , the
参考图10,支腿总成25由螺杆组件67、挡板68和铰座69组成。其中,螺杆组件67的球头安装在通过螺栓连接的挡板68与铰座69之间;铰座69可用于支撑伸缩臂2;该螺杆组件67的螺杆通过扁担梁26上的螺旋套筒的旋合运动,实现在其上的铰座69升降;从而实现支腿总成25总长度的可变。因此,可利用在较短的长度放到支撑点处后,通过旋合运动,实现铰座69上升,从而支撑伸缩臂2,以方便驮梁小车1在伸缩臂2行走。Referring to FIG. 10 , the
扁担梁26由支撑梁和设置于支撑梁内的螺旋套筒组成。主要是在从运梁车取梁时,螺杆组件67承受的力很大,而螺杆组件67的面积较小,若是直接支撑在桥面上,很容易损坏桥面,而扁担梁26的支撑梁可实现增大与桥面的接触面积,从而减少压强。The
参考图4,横梁总成3主要由上反扣支座31、移运器总成32、横梁33、插销支座34、变跨油缸总成35、插销36、导向支座总成37、下反扣支座38和下反扣螺杆39组成。其中,上反扣支座31、移运器总成32、插销支座34、插销36和导向支座总成37位于横梁33上表面;变跨油缸总成35位于横梁33侧面,下反扣支座38和下反扣螺杆39位于横梁33下表面;横梁33置于门型架4之上,与门型架4之间可以通过变跨油缸总成35实现相对滑动,从而完成不同跨度的箱梁对伸缩臂2中心距变化要求;移运器总成32可使伸缩臂2在其上左右滚动,完成伸缩作业。Referring to Fig. 4, the crossbeam assembly 3 mainly consists of an upper
上反扣支座31的主要能实现防止伸缩臂2在伸缩时出现伸缩臂2及其上的前后倾翻;且通过卡住挡块27来控制伸缩臂2的最大伸缩量从而控制转运平台重心偏离支撑点的最大距离,以防止出现整个转运平台的前后倾翻。The
移运器总成32的具体结构参考图11,移运器总成32由滚子移运器70、橡胶垫板71、调整垫板72、安装底座73和连接螺栓74组成。其中,滚子移运器70安装在橡胶垫板71上,利用橡胶垫板71的弹性进行减震,橡胶垫板71安装于调整垫板72上,调整垫板72安装于安装底座73上,它们相互之间通过连接螺栓74实现连接,需要时,也可以除去调整垫板72,以调整相对高度,该移运器总成32主要实现将其上面伸缩臂2与其下面的横梁33的相对运动变为滚动。Referring to FIG. 11 for the specific structure of the
变跨油缸总成35由变跨油缸耳座75、变跨油缸76、变跨油缸滑座77构成。The variable-span
变跨油缸耳座75与横梁33侧面焊接连接,变跨油缸76通过销连接与变跨油缸耳座75和变跨油缸滑座77进行连接,变跨油缸滑座77通过螺栓与门型架4连接。而门型架4上盖板上有多组螺纹孔,在变跨时,变跨油缸滑座77通过螺栓、门型架4上盖板的螺纹孔与门型架4连接,通过变跨油缸76的伸缩,带动变跨油缸耳座75伸缩,从而实现横梁33的伸缩。The variable-span oil
通过变跨油缸总成35的设置,使得本发明的转运平台可以实现不同变跨工序,众所周知,不可能所有的箱梁的尺寸均相同,梁片的长度有32m、29m、24m等不同的尺寸,而本转运平台通过变跨工序,可以调整横梁总成3的距离,从而可同时转运各种长度的梁片。Through the setting of the variable-span
参考图5,门型架4采用门型结构,由两根箱形结构主梁41、多个支腿42和多个连接梁43组成,连结梁43连接两根主梁以提高强度,保证整个伸缩移运作业过程的稳定性。其中主梁41为了方便运输,分为左主梁节段和右主梁节段,节段端部的连接部分和连接板的表面喷砂后涂无机富锌漆,采用10.9级高强度螺栓连接方式,实现两节主梁对接。支腿42通过与主梁螺栓连接,与预埋基础焊接连接,保证整个转运平台作业过程的稳定性。Referring to Fig. 5, the portal frame 4 adopts a portal structure, and is composed of two box-shaped main beams 41, a plurality of supporting legs 42 and a plurality of connecting
参考图6,驱动系统由驱动装置51、左导向轮52、右导向轮53和滚子链54组成,用来驱动伸缩臂2和驮梁小车1伸缩,滚子链54一端通过驮梁小车1上的可调链条安装座13与驮梁小车1的台车架12连接,经过驱动装置51、安装在伸缩臂2上的右导向轮53、左导向轮52,最后通过驮梁小车1上的可调链条安装座13与驮梁小车1另一端的台车架12连接。由驱动装置51的电机提供动力,驱动减速机带动链轮转动,从而带动滚子链54,从而带动驮梁小车1的左右移动。Referring to Fig. 6, the driving system is composed of a driving device 51, a
参考图7,伸缩控制装置包括驮梁小车1上的销固定支座16和滚轮装置17、通过法兰板固定在横梁33上的插销36、插销支座34、移运器总成32以及伸缩臂2上的插销套筒组成。通过插销36在销固定支座16和插销套筒的位置不同,实现驮梁小车1或伸缩臂2移动。举例来说,当插销36通过插销支座34插到驮梁小车1上的销固定支座16上时,驮梁小车1与横梁33保持固定,则驱动系统5能驱动伸缩臂2伸缩,而当插销36通过插销支座34插入伸缩臂2上的插销套筒时,伸缩臂2相对横梁33保持固定,则驱动系统5能驱动驮梁小车1运动行走,由此,该伸缩控制装置能通过插销36在驮梁小车1和伸缩臂2的不同位置,实现在不同需求时通过驱动系统驱动伸缩臂2伸缩或驮梁小车1行走。Referring to Fig. 7, the telescopic control device includes the
图8显示了本发明移梁工序的示意图,由图8可知,本发明的转运平台的移梁工序如下:Fig. 8 has shown the schematic diagram of the beam-moving process of the present invention, as can be seen from Fig. 8, the beam-moving process of the transfer platform of the present invention is as follows:
a、伸缩臂伸缩到桥面外侧,让开桥面通道;运梁车运载箱梁至转运平台对位(参见图8A);a. The telescopic arm stretches to the outside of the bridge deck to get out of the way of the bridge deck passage; the girder truck carries the box girder to the transfer platform for alignment (see Figure 8A);
b、伸缩臂伸入至桥面,安装螺旋支承(参见图8B);b. The telescopic arm is extended to the bridge deck, and the screw support is installed (see Figure 8B);
c、驮梁小车行走至箱梁下方对位,运梁车落梁,箱梁落放在驮梁小车支座上,运梁车卸载(参见图8C);c. The carrying beam trolley walks to the position below the box girder, the beam transporting vehicle drops the beam, the box girder falls on the support of the carrying beam trolley, and the beam transporting vehicle unloads (see Figure 8C);
d、驮梁小车驮运箱梁到桥面外侧(参见图8D);d, the beam trolley carries the box girder to the outside of the bridge deck (see Figure 8D);
e、撤除螺旋支承,伸缩臂伸缩到桥面外侧,运梁车返回梁场取梁(参见图8E);e. Remove the screw support, stretch the telescopic arm to the outside of the bridge deck, and return the beam truck to the beam field to take the beam (see Figure 8E);
f、运架一体架桥机空载运行至转运平台对位;f. The transport-frame integrated bridge erecting machine runs without load to the alignment of the transfer platform;
g、伸缩臂伸出至桥面,安装螺旋支承;g. The telescopic arm is stretched out to the bridge deck, and the screw support is installed;
h、驮梁小车驮运箱梁至运架一体架桥机下方(工序f、g、h参见图8F);h. The beam trolley carries the box girder to the bottom of the integrated bridge erecting machine (see Figure 8F for procedures f, g, and h);
i、运架一体架桥机吊起箱梁(参见图8G);i, transport frame integrated bridge erecting machine to lift the box girder (see Figure 8G);
j、驮梁小车空载运行到桥面外侧,撤除螺旋支承,伸缩臂移到桥面外侧,让开桥面通道,运架一体架桥机前行架梁(参见图8H)。j. The girder trolley runs to the outside of the bridge deck with no load, removes the screw support, moves the telescopic arm to the outside of the bridge deck, clears the bridge deck passage, and transports the integrated bridge erecting machine to the front girder (see Figure 8H).
采用本发明的转运平台在预制梁场进行的装梁工序包括以下步骤:The beam loading process carried out in the prefabricated beam field by using the transfer platform of the present invention comprises the following steps:
a、提梁机从预制梁场提取梁片,并放到转运平台上;a. The beam lifting machine extracts the beam pieces from the prefabricated beam field and puts them on the transfer platform;
b、运架一体架桥机空载运行至转运平台对位;b. The integrated bridge erecting machine runs without load to the alignment of the transfer platform;
c、将转运平台伸缩臂伸出至桥面,安装螺旋支承;c. Extend the telescopic arm of the transfer platform to the bridge deck and install the screw support;
d、驮梁小车驮运箱梁横移至运架一体架桥机下方;d. The beam trolley carries the box girder and moves to the lower part of the integrated bridge erecting machine;
e、运架一体架桥机吊起箱梁;e. The box girder is lifted by the integrated bridge erecting machine;
f、驮梁小车空载运行到桥面外侧,撤除螺旋支承,伸缩臂移到桥面外侧,让开桥面通道,运架一体架桥机前行架梁。f. The beam trolley runs to the outside of the bridge deck with no load, removes the screw support, moves the telescopic arm to the outside of the bridge deck, clears the bridge deck passage, and transports the integrated bridge erecting machine to erect the girder.
其中:伸缩臂伸缩到桥面外侧或提梁机从预制梁场提取梁片时,转运平台根据待转运箱梁的规格,已完成变跨工序,该变跨工序包括以下步骤:Among them: when the telescopic arm stretches to the outside of the bridge deck or the girder lifting machine picks up the girder pieces from the prefabricated girder field, the transfer platform has completed the span-changing process according to the specifications of the box girder to be transferred. The span-changing process includes the following steps:
a、将伸缩臂和驮梁小车停止在重心位于门架中心;a. Stop the telescopic arm and the beam trolley when the center of gravity is at the center of the mast;
b、将下反扣的四个顶紧丝杆松开;b. Loosen the four top tightening screw rods of the bottom buckle;
c、不断更换油缸座的位置,直到变跨作业完成。c. Change the position of the oil cylinder seat continuously until the span change operation is completed.
通过上述装梁工序,由于在运架一体架桥机到达预制梁场前,提梁机就可以从预制梁场提取梁片,并放到转运平台上,准备装梁。因此,进一步节省了时间,提高了效率。Through the above-mentioned beam loading process, before the integrated bridge erecting machine reaches the prefabricated beam yard, the beam lifting machine can extract the beam pieces from the prefabricated beam yard and put them on the transfer platform to prepare for beam loading. Therefore, time is further saved and efficiency is improved.
Claims (9)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201010146619 CN101818480B (en) | 2010-04-15 | 2010-04-15 | Box girder transfer platform and girder transferring and girder loading working procedures thereof |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201010146619 CN101818480B (en) | 2010-04-15 | 2010-04-15 | Box girder transfer platform and girder transferring and girder loading working procedures thereof |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN101818480A CN101818480A (en) | 2010-09-01 |
| CN101818480B true CN101818480B (en) | 2012-08-01 |
Family
ID=42653737
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN 201010146619 Expired - Fee Related CN101818480B (en) | 2010-04-15 | 2010-04-15 | Box girder transfer platform and girder transferring and girder loading working procedures thereof |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN101818480B (en) |
Families Citing this family (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102409615A (en) * | 2011-09-09 | 2012-04-11 | 腾达建设集团股份有限公司 | Pier top beam moving mechanism |
| CN103603271B (en) * | 2013-03-27 | 2016-01-20 | 郑州市大方实业有限公司 | A kind of installation construction of double combined combined bridge |
| CN105887687B (en) * | 2016-04-25 | 2017-08-15 | 中铁十七局集团第三工程有限公司 | A kind of method for dismantling lifting beam main beam |
| CN107386128A (en) * | 2017-09-15 | 2017-11-24 | 中铁第五勘察设计院集团有限公司 | Double-T shaped beam bridge changes beam construction system |
| CN108086162B (en) * | 2017-12-14 | 2019-06-28 | 南京交通工程有限公司 | A kind of trolley traversing for box beam and the box girder construction engineering method using the trolley |
| CN108239936B (en) * | 2018-02-09 | 2024-01-12 | 中铁工程机械研究设计院有限公司 | U-shaped tunneling beam truck with adjustable wheel track and beam feeding method thereof |
| CN110273371B (en) * | 2018-03-17 | 2024-04-30 | 中铁第五勘察设计院集团有限公司 | Transport and frame integrated machine |
| CN109183620B (en) * | 2018-09-05 | 2024-07-19 | 广东省长大公路工程有限公司 | Telescopic bracket, steel box girder hoisting equipment and hoisting method |
| CN109024561A (en) * | 2018-10-07 | 2018-12-18 | 中交路桥建设有限公司 | A kind of flange form connection structure at steel-pipe pile top and I-shaped gooseneck |
| CN109629456B (en) * | 2019-01-16 | 2024-03-22 | 中交一公局海威工程建设有限公司 | Precast beam sideslip device and precast beam sideslip system |
| CN110055902B (en) | 2019-05-23 | 2020-12-22 | 中铁二局集团有限公司 | Large-tonnage box girder normal position lifting beam bridge erecting construction method and erection method thereof |
| CN111335143B (en) * | 2019-12-12 | 2024-07-19 | 中国船舶重工集团应急预警与救援装备股份有限公司 | Telescopic arm module for mechanized bridge erection |
| CN111497603B (en) * | 2019-12-25 | 2021-09-17 | 北京丰达汽车部件有限公司 | Oil tank bracket and production process thereof |
| CN111851315A (en) * | 2020-08-24 | 2020-10-30 | 中铁工程机械研究设计院有限公司 | Outrigger device of a bridge erecting machine and bridge erecting machine |
| CN113339021B (en) * | 2021-05-31 | 2022-11-04 | 中铁工程服务有限公司 | Complete equipment for accurately assembling secondary lining steel bars in mountain tunnel |
| CN115057184B (en) * | 2022-07-08 | 2023-11-03 | 山东大学 | Large-scale prefabricated case roof beam conveyer |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0460004A (en) | 1990-06-27 | 1992-02-26 | Mitsui Miike Mach Co Ltd | Mobile scaffolding device for bridges |
| JPH10245817A (en) | 1997-03-04 | 1998-09-14 | Honsyu Shikoku Renrakukiyou Kodan | Transfer platform having core adjusting mechanism |
| CN2617815Y (en) * | 2003-05-13 | 2004-05-26 | 中铁工程机械研究设计院 | PC rail beam transportation rack device for light railing communication |
| CN201087323Y (en) * | 2007-09-11 | 2008-07-16 | 中铁二局股份有限公司 | Mobile integral construction platform |
| CN101476291A (en) * | 2009-01-21 | 2009-07-08 | 中铁一局集团有限公司 | Segment-assembling simply supported box girder movable falsework construction method |
-
2010
- 2010-04-15 CN CN 201010146619 patent/CN101818480B/en not_active Expired - Fee Related
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0460004A (en) | 1990-06-27 | 1992-02-26 | Mitsui Miike Mach Co Ltd | Mobile scaffolding device for bridges |
| JPH10245817A (en) | 1997-03-04 | 1998-09-14 | Honsyu Shikoku Renrakukiyou Kodan | Transfer platform having core adjusting mechanism |
| CN2617815Y (en) * | 2003-05-13 | 2004-05-26 | 中铁工程机械研究设计院 | PC rail beam transportation rack device for light railing communication |
| CN201087323Y (en) * | 2007-09-11 | 2008-07-16 | 中铁二局股份有限公司 | Mobile integral construction platform |
| CN101476291A (en) * | 2009-01-21 | 2009-07-08 | 中铁一局集团有限公司 | Segment-assembling simply supported box girder movable falsework construction method |
Also Published As
| Publication number | Publication date |
|---|---|
| CN101818480A (en) | 2010-09-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN101818480A (en) | Box girder transfer platform and girder transferring and girder loading working procedures thereof | |
| US20210332533A1 (en) | Novel track layer for urban track traffic engineering and its construction method | |
| CN207498755U (en) | A kind of traveling trolley adjusted with horizontal extension and vertical supporting | |
| CN110655015A (en) | A trackless self-propelled platform vehicle for subway tunnel maintenance | |
| CN1311134C (en) | Down beam type bridge-erecting machine and bridge erecting method thereof | |
| CN109024291A (en) | A kind of integration Bridge Erector and its working method | |
| CN207498754U (en) | A kind of novel track-laying machine of city track traffic engineering | |
| CN110541347B (en) | Large-span fully hydraulic tire walking tunnel inverted arch trestle and construction method | |
| WO2022001169A1 (en) | Highway-railway dual-purpose track-laying machine for urban rail transit engineering | |
| CN110778133A (en) | Special-shaped space truss installation sliding track structure and construction process thereof | |
| CN116553372A (en) | Lifting equipment for bridge construction and bridge construction method | |
| CN111776950A (en) | A cantilever telescopic hoisting frame gantry device | |
| CN103787203B (en) | For installing the bracing frame of precast beam jack | |
| CN100572673C (en) | Span continuous beam bridge fabrication machine in a kind of | |
| CN201730052U (en) | Box girder transfer equipment | |
| CN114476962A (en) | A steel-concrete composite beam erection system based on bridge deck crane | |
| CN203602254U (en) | Support frame for installing precast beam jack | |
| CN110804958B (en) | A method for changing the frame of a whole-hole beam | |
| CN202415024U (en) | Crane capable of climbing over beam-arch, climbing up slope and climbing down slope | |
| CN111719358A (en) | A dual-purpose track laying machine for urban rail transit engineering and its use method | |
| CN111706051A (en) | Steel beam installation rail-type mobile operation platform and installation method of steel beam under high voltage line | |
| CN110777681A (en) | Whole hole roof beam trades a equipment | |
| CN211079881U (en) | Long-span full hydraulic tire walking tunnel inverted arch trestle | |
| CN206245344U (en) | An installation vehicle used for assembling prefabricated and assembled comprehensive pipe gallery | |
| CN205418901U (en) | Prefab conveyer |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| ASS | Succession or assignment of patent right |
Owner name: CHINA RAILWAY ENGINEERING MACHINERY RESEARCH + DES Free format text: FORMER OWNER: CHINA RAILWAY SCIENCE + INDUSTRY GROUP CO., LTD. Effective date: 20150421 |
|
| C41 | Transfer of patent application or patent right or utility model | ||
| COR | Change of bibliographic data |
Free format text: CORRECT: ADDRESS; FROM: 430066 WUHAN, HUBEI PROVINCE TO: 430077 WUHAN, HUBEI PROVINCE |
|
| TR01 | Transfer of patent right |
Effective date of registration: 20150421 Address after: 430077 Hongshan, Wuhan, Xu Xu East Street, No. 55 Patentee after: CHINA RAILWAY ENGINEERING MACHINERY RESEARCH & DESIGN INSTITUTE Co.,Ltd. Address before: 430066, 45 East Main Street, Wuchang District, Hubei, Wuhan Patentee before: CHINA RAILWAY SCIENCE & INDUSTRY GROUP Co.,Ltd. |
|
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20120801 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |