WO2020162530A1 - 電動駆動装置 - Google Patents
電動駆動装置 Download PDFInfo
- Publication number
- WO2020162530A1 WO2020162530A1 PCT/JP2020/004506 JP2020004506W WO2020162530A1 WO 2020162530 A1 WO2020162530 A1 WO 2020162530A1 JP 2020004506 W JP2020004506 W JP 2020004506W WO 2020162530 A1 WO2020162530 A1 WO 2020162530A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- circuit board
- spacer
- drive device
- electric drive
- circuit
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B62—LAND VEHICLES FOR TRAVELLING OTHERWISE THAN ON RAILS
- B62D—MOTOR VEHICLES; TRAILERS
- B62D5/00—Power-assisted or power-driven steering
- B62D5/04—Power-assisted or power-driven steering electrical, e.g. using an electric servo-motor connected to, or forming part of, the steering gear
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02K—DYNAMO-ELECTRIC MACHINES
- H02K11/00—Structural association of dynamo-electric machines with electric components or with devices for shielding, monitoring or protection
- H02K11/30—Structural association with control circuits or drive circuits
- H02K11/33—Drive circuits, e.g. power electronics
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02K—DYNAMO-ELECTRIC MACHINES
- H02K5/00—Casings; Enclosures; Supports
- H02K5/04—Casings or enclosures characterised by the shape, form or construction thereof
- H02K5/22—Auxiliary parts of casings not covered by groups H02K5/06-H02K5/20, e.g. shaped to form connection boxes or terminal boxes
Definitions
- the present invention relates to an electric drive device, and more particularly to an electric drive device having an electronic control unit built-in.
- a mechanical system control element is driven by an electric motor, but recently, an electronic control unit including a semiconductor element for controlling a rotation speed and a rotation torque of the electric motor is electrically driven.
- a so-called electromechanical integrated electric drive device which is integrally incorporated into a motor, has begun to be adopted.
- the electromechanical integrated electric drive device for example, in an electric power steering device of an automobile, a driver operates a steering wheel to detect a turning direction and a turning torque of a turning steering shaft, Based on the detected value, the electric motor is driven so as to rotate in the same direction as the rotation direction of the steering shaft, and the steering assist torque is generated.
- an electronic control unit ECU: Electronic Control Unit
- ECU Electronic Control Unit
- Patent Document 1 describes an electric power steering device including an electric motor unit and an electronic control unit.
- an electric drive device in which an electronic control device is integrated, an electric brake, an electric hydraulic controller for various hydraulic controls, and the like are known. explain.
- control circuit board and the power supply circuit board are stacked and arranged, and these circuit boards are separately fixed to the end wall of the motor housing by fixing bolts. ..
- the power supply circuit board is arranged closer to the end surface wall side of the motor housing than the control circuit board, but the control circuit board is arranged closer to the end surface wall side of the motor housing than the power supply circuit board. The same applies when there is.
- control circuit board and the power supply circuit board are arranged in a stacked manner and fixed to the fixing bosses with fixing bolts.
- fixing area for fixing the board becomes large and the mounting area of the electronic component and the electric component is reduced.
- An object of the present invention is to provide a novel electric drive device capable of enlarging the mounting area of electronic components and electric components of the circuit boards located on the end face wall side of the motor housing in the circuit boards arranged in a stack. Especially.
- the present invention is A circuit part for driving the electric motor, which is arranged on the end face wall of the motor housing opposite to the output part of the rotary shaft of the electric motor and the motor housing that houses the electric motor for driving the mechanical system control element. And at least two first and second circuit boards mounted with, spacers of a predetermined length interposed between the respective circuit boards, and a connector assembly connected to the respective circuit boards, The first circuit board, the spacer, the second circuit board, and the connector assembly are arranged in this order from the end wall of the motor housing in the axial direction of the rotating shaft of the electric motor,
- the common fixing member is fixed to the end surface wall of the motor housing from the connector assembly side through the through holes provided in the connector assembly, the second circuit board, the spacer, and the first circuit board. Is characterized by.
- the present invention is A circuit part for driving the electric motor, which is arranged on the end face wall of the motor housing opposite to the output part of the rotary shaft of the electric motor and the motor housing that houses the electric motor for driving the mechanical system control element.
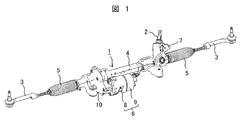
- FIG. 1 is an overall perspective view of an electric power steering device to which the present invention is applied.
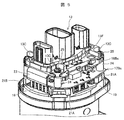
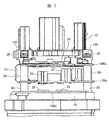
- 1 is an exploded perspective view of an electric power steering device according to a first embodiment of the present invention. It is the side view which looked at the electronic control part which removed the cap cover from the electric power steering device shown in Drawing 3 from the side. It is the perspective view which looked at the electronic control part of FIG. 4 from diagonally upward. It is sectional drawing which shows the modification of a spacer. It is the side view which looked at the electronic control part which removed the cap cover from the electric power steering device which becomes a 2nd embodiment of the present invention from the side.
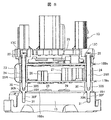
- FIG. 8 is a cross-sectional view of the electronic control unit of FIG. 7 taken along a direction in which a common fixing bolt extends.
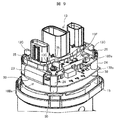
- FIG. 8 is a perspective view of the electronic control unit of FIG. 7 viewed from diagonally above.
- the steering device 1 is configured as shown in FIG.
- a pinion (not shown) is provided at the lower end of the steering shaft 2 connected to a steering wheel (not shown), and this pinion meshes with a rack (not shown) that is long in the left-right direction of the vehicle body.
- Tie rods 3 for steering the front wheels to the left and right are connected to both ends of this rack, and the rack is covered with a rack housing 4.
- a rubber boot 5 is provided between the rack housing 4 and the tie rod 3.
- An electric power steering device 6 is provided to assist the torque when rotating the steering wheel. That is, the torque sensor 7 that detects the rotation direction and the rotation torque of the steering shaft 2 is provided, and the electric motor unit 8 that applies the steering assist force to the rack via the gear 10 based on the detection value of the torque sensor 7. And an electronic control unit 9 for controlling the electric motor arranged in the electric motor unit 8.
- the electric motor unit 8 of the electric power steering device 6 is connected to the gear 10 through three bolts (not shown) on the outer peripheral portion on the output shaft side, and the electronic control unit 9 is provided on the opposite side of the electric motor 8 unit from the output shaft. Is provided.
- the torque sensor 7 indicates the turning direction and turning torque of the steering shaft 2.
- the control circuit unit of the electronic control unit 9 calculates the drive operation amount of the electric motor based on the detected value.
- the electric motor is driven by the power switching element of the power conversion circuit unit of the electronic control unit 9 so that the output shaft of the electric motor rotates in the same direction as the operation direction of the steering shaft 2. Driven to. The rotation of the output shaft is transmitted from a pinion (not shown) to a rack (not shown) via the gear 10 to steer the vehicle. Since their configurations and operations are already well known, further description will be omitted.
- Patent Document 1 when the control circuit board and the power supply circuit board are stacked and arranged and fixed to the fixing boss with fixing bolts, the circuit board arranged close to the end face wall of the motor housing is different from the other circuit.
- the fixing boss of the board is cut out, and the mounting area of electronic parts and electric parts is reduced accordingly.
- a head receiving area for receiving the head of the fixing bolt is required, which also reduces the mounting area of electronic parts and electric parts. Therefore, it is required to increase the mounting area of electronic components and electric components of the circuit boards arranged closer to the end surface wall of the motor housing in the circuit boards arranged in layers.
- the present embodiment proposes an electric power steering device having the following configuration.
- first and first sheets which are arranged on the side of the end surface wall of the motor housing opposite to the output portion of the rotary shaft of the electric motor and mounted with circuit components for driving the electric motor, are provided.
- the first circuit board, the spacer, the second circuit board, and the connector assembly are arranged in this order from the end face wall, and the common fixing member is from the connector assembly side to the connector assembly and the second circuit.
- the board, the spacer, and the through hole provided in the first circuit board are inserted and fixed to the end surface wall of the motor housing.
- the first circuit board, the spacer, the second circuit board, and the connector assembly are arranged in this order in the axial direction of the rotary shaft of the electric motor in the direction away from the end wall of the motor housing.
- the common fixing member is inserted into the end face wall of the motor housing from the connector assembly side through the through holes provided in the connector assembly, the second circuit board, the spacer, and the first circuit board. Since they are fixed, it is possible to increase the mounting area of electronic components and electric components of the circuit boards located on the end face wall side of the motor housing among the circuit boards arranged in layers.
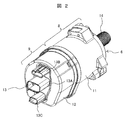
- FIGS. 2 to 5 is a drawing showing the overall structure of the electric power steering device according to the present embodiment
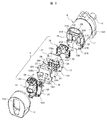
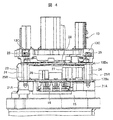
- FIG. 3 is a drawing of the components of the electric power steering device shown in FIG. 4 is a side view of the electronic control unit with the cap cover removed
- FIG. 5 is a plan view of the electronic control unit of FIG. 4 seen obliquely from above.
- the electric motor unit 8 constituting the electric power steering device 6 is composed of a motor housing 11 having a tubular portion made of aluminum alloy or the like, and an electric motor (not shown) housed in the motor housing 11.
- the electronic control unit includes a cap cover 12 made of aluminum alloy or the like, which is arranged on the opposite side of the motor housing 11 from the output shaft 14 in the axial direction, and an electronic control unit 9 housed in the cap cover 12. ing.
- the motor housing 11 and the cap cover 12 are integrally fixed at their opposing end faces by an adhesive, welding, or a fixing bolt.
- the electronic control unit 9 stored in the storage space inside the cap cover 12, although not specifically shown, is a power supply circuit unit that generates a necessary power supply, a MOSFET that drives and controls the electric motor of the electric motor unit 8, or It is composed of a power conversion circuit section having a power switching element such as an IGBT and a control circuit section for controlling this power switching element, and the output terminal of the power switching element and the coil input terminal of the electric motor are electrically connected via a bus bar. It is connected.
- a connector assembly 13 is provided on the end surface of the cap cover 12.
- the connector assembly 13 includes a connector terminal forming portion 13A for supplying electric power, a connector terminal forming portion 13B for detecting sensors, and a control state transmitting connector terminal forming portion 13C for transmitting a control state to an external device.
- the electronic control unit 9 housed in the cap cover 12 is supplied with electric power from a power source through a connector terminal forming unit 13A for supplying electric power, which is made of synthetic resin, and the detection sensors detect an operating state or the like.
- the signal is supplied through the connector forming terminal portion 13B for the detection sensor, and the current control state signal of the electric power steering device is sent out through the connector terminal forming portion 13C for sending the control state.
- FIG. 3 shows an exploded perspective view of the electric power steering device 6.
- An annular iron side yoke (not shown) is fitted inside the motor housing 11, and an electric motor (not shown) is housed in the side yoke.
- the output unit 14 of the electric motor applies a steering assist force to the rack via a gear. Since the specific structure of the electric motor is well known, its explanation is omitted here.
- the motor housing 11 is made of aluminum alloy and functions as a heat sink member that releases the heat generated by the electric motor and the heat generated by the power supply circuit section and the power conversion circuit section, which will be described later, to the outside atmosphere.
- the electric motor and the motor housing 11 constitute the electric motor unit 8.
- An end surface wall 15 of the motor housing 11 is formed on the opposite side of the output portion 14 of the electric motor portion 8, and the electronic control portion 9 is attached to the end surface wall 15.
- the electronic control unit 9 includes a power conversion circuit unit 16, a power supply circuit unit 17, and a control circuit unit 18.
- the end wall 15 of the motor housing 11 functions as a heat sink and is formed integrally with the motor housing 11. However, in addition to this, only the end wall 15 is separately formed and integrated with the motor housing 11 by bolts or welding. It's good.
- the power conversion circuit unit 16, the power supply circuit unit 17, and the control circuit unit 18 form a redundant system, and form a dual system of a main electronic control unit and a sub electronic control unit.
- the electric motor is usually controlled and driven by the main electronic control unit.
- the sub electronic control unit is switched to control and drive the electric motor.
- heat from the main electronic control unit is transferred to the motor housing 11, and if an abnormality or failure occurs in the main electronic control unit, the main electronic control unit stops and the sub electronic control unit operates, and the motor housing 11 The heat from the sub electronic control unit is transmitted to.
- the main electronic control unit and the sub electronic control unit are combined to function as a regular electronic control unit, and when one electronic control unit has an abnormality or a failure, the other electronic control unit has more than half of the electronic control unit. It is also possible to control and drive the electric motor according to the ability.
- the electronic control unit 9 includes a control circuit unit 18, a power supply circuit unit 17, a power conversion circuit unit 16, and a connector assembly 13, and extends in the axial direction of the motor housing 11 away from the end wall 15 side.
- the power conversion circuit unit 16, the power supply circuit unit 17, the control circuit unit 18, and the connector assembly 13 are arranged in this order.
- the axis line of the motor housing means an axis line that substantially coincides with the center line of the rotation shaft of the electric motor housed in the motor housing 11, and hereinafter, the axis line of the motor housing is simply referred to as the axis line. In some cases.
- the control circuit unit 18 generates a control signal for driving the power switching element of the power conversion circuit unit 16, and is composed of a microcomputer and peripheral circuits.
- the power supply circuit unit 17 generates a power supply for the control circuit unit 18 and a power supply for the power conversion circuit unit 16, and is composed of a capacitor, a coil, a power switching element, and the like.
- the power conversion circuit unit 16 adjusts the electric power flowing through the coil of the electric motor, and is composed of a power switching element or the like that constitutes upper and lower arms of three phases.
- Circuit parts such as electric parts and electronic parts that constitute the control circuit part 18 and the power supply circuit part 17 are mounted on the surface of a circuit board made of a glass epoxy board, and these circuit boards are mounted on the rotating shaft of the electric motor. Are arranged in a radial direction orthogonal to the.
- the control circuit unit 18, the power supply circuit unit 17, and the power conversion circuit unit 16 are arranged so as to be sequentially stacked in the axial direction.
- the heat generation amount is large in the electronic control unit 9 mainly in the power conversion circuit unit 16 and the power supply circuit unit 17, and the heat of the power conversion circuit unit 16 and the power supply circuit unit 17 is radiated from the motor housing 11 made of aluminum alloy. To be done.
- the power conversion circuit section 16 is closely attached to the end wall 15 of the motor housing 11.
- the power conversion circuit unit 16 is configured to be attached in close contact with the end face wall 15 by the fixing member 20 having a resilient function. That is, the elastic function member formed on the fixing member 20 presses the power conversion circuit section 16 toward the heat radiation section formed on the end wall 15 side of the motor housing 11, and the power conversion circuit section 16 acts as the heat radiation section. Pressed and held.
- a connector assembly 13 made of synthetic resin is arranged between the control circuit section 18 and the cap cover 12, and is connected to a vehicle battery (power source) and other external control devices (not shown).
- the connector assembly 13 is appropriately connected to the power conversion circuit unit 16, the power supply circuit unit 17, and the control circuit unit 18.
- the cap cover 12 has a function of accommodating the power conversion circuit unit 16, the power supply circuit unit 17, and the control circuit unit 18 and sealing them in a liquid-tight manner. It is fixed to the end wall 15 of the motor housing 11. Since the cap cover 12 is made of metal, it also has a function of radiating the heat generated by the power conversion circuit unit 16, the power supply circuit unit 17 and the like to the outside.
- An opening 12A is formed in the cap cover 12, and the connector terminal forming portions 13A to 13C of the connector assembly 13 are exposed from the opening 12A.
- the connector assembly 13 is in close contact with the edge of the opening 12A, and a 0-ring or a liquid sealant is placed in this close contact portion to achieve liquid tightness.
- Heat dissipation areas 15A and 15B of the power conversion circuit unit 16 and the power supply circuit unit 17 are formed on the surface of the end wall 15 located on the side opposite to the output unit 14 of the electric motor.
- Substrate fixing portions 21A and 21B having the same height are integrally formed at the four corners of the end wall 15, and bolt screw holes 21S are formed inside.
- the board fixing portions 21A and 21B are provided to mount the power supply circuit board (corresponding to the first circuit board) 17Bs of the power supply circuit section 17.
- the board fixing portion 21A is formed by being erected from the power conversion heat radiation area 15A, and the board fixing portion 21B is formed in the power supply heat radiation area 15B.
- the board fixing portion 21B formed in the power radiation area 15B is a board fixing portion 21B including the power radiation area 15B.
- the plane area forming the end wall 15 in the radial direction orthogonal to the axis is divided into two.
- One forms a power conversion heat dissipation area 15A to which the power conversion circuit section 16 is attached
- the other forms a power supply heat dissipation area 15B to which the power supply circuit section 17 is attached.
- the power conversion heat dissipation area 15A is formed to have a larger area than the power supply heat dissipation area 15B. This is to secure the installation area of the power conversion circuit unit 16 because the dual system is adopted as described above.
- the power conversion heat dissipation area 15A and the power supply heat dissipation area 15B are in the form of steps having different heights in the axial direction.
- the heat dissipation area 15B for power supply is formed in a step-like manner in a direction away from the heat dissipation area 15A for power conversion when viewed in the axial direction.
- This step is set to a length such that the power conversion circuit unit 16 and the power supply circuit unit 17 do not interfere with each other when the power supply circuit unit 17 is installed after the power conversion circuit unit 16 is installed.
- a dual power conversion circuit unit 16 is installed on the projecting heat dissipation unit 22.
- the projecting heat dissipating portion 22 projects and extends in a direction away from the electric motor when viewed in the axial direction.
- the heat radiation area 15B for power supply is flat, and the power supply circuit board 17Bs of the power supply circuit unit 17 is installed. Further, an extended heat radiation area 15C extending toward the center side of the rotating shaft of the electric motor is formed in the power radiation area 15B. This is because when the three power conversion circuit units 16 are mounted on the protruding heat dissipation unit 22 in a “U” shape, the space where the power conversion circuit unit 16 does not exist is used as the heat dissipation region of the power supply circuit unit 17. It is formed to
- the projecting heat dissipation portion 22 functions as a heat dissipation portion that transfers the heat generated in the power conversion circuit portion 16 to the end surface wall 15, and the power supply heat dissipation area 15B transmits the heat generated in the power supply circuit portion 17 to the end surface wall. It functions as a heat radiating portion that transfers heat to 15.
- the projecting heat dissipation part 22 can be omitted, and in this case, the power conversion heat dissipation region 15A functions as a heat dissipation part that transfers the heat generated in the power conversion circuit part 16 to the end wall 15.
- the heat sink member can be omitted in the end wall 15 of the motor housing 11 according to the present embodiment, the axial length can be shortened. Further, since the motor housing 11 has a sufficient heat capacity, the heat of the power supply circuit section 17 and the power conversion circuit section 16 can be efficiently radiated to the outside.
- the power supply circuit unit 17 is installed from the upper side of the power conversion circuit unit 16, but in this case, the power supply circuit board 17Bs of the power supply circuit unit 17 is installed on the upper part of the heat dissipation area 15B for power supply. Capacitors, coils, and the like forming the power supply circuit unit 17 are mounted on the power supply circuit board 17Bs made of a glass epoxy board.
- the power supply circuit section 17 also employs a dual system, and as can be seen from the drawing, the power supply circuit including capacitors and coils is formed in line symmetry.
- the surface of the power supply circuit board 17Bs on the power dissipation area 15B side is fixed to the end wall 15 so as to contact the power dissipation area 15B.
- the fixing method is fixed by screwing an elongated "common fixing bolt” (which will be described later) having an elongated shape that functions as a "common fixing member” into the bolt screw holes 21S provided in the board fixing portions 21A and 21B. .. Therefore, through holes 17H corresponding to the positions of the bolt screw holes 21S of the board fixing portions 21A and 21B are formed at the four corners of the power circuit board 17Bs.
- the power supply circuit board 17Bs is fixed by a common fixing bolt which will be described later, and a notch that matches the shape of the fixing boss that fixes the control circuit board as in Patent Document 1 is not formed. Similarly, since the power supply circuit board is fixed to the fixing boss, the head receiving region of the fixing bolt screwed into the fixing boss is not formed. Therefore, it is possible to increase the mounting area of the electronic components and electric components of the power supply circuit board 17Bs located on the end wall 15 side of the motor housing.
- the power supply circuit board 17Bs of the power supply circuit unit 17 is formed of a glass epoxy board, which enables double-sided mounting. Then, on the surface of the power supply circuit board 17Bs on the side of the heat radiation area 15B for power supply, a rotation phase and a rotation speed detection unit including a GMR element (not shown), a detection circuit thereof, and the like are mounted and provided on the rotation shaft of the electric motor. The rotation phase and the rotation speed of the rotation shaft are detected in cooperation with the rotation detector.
- the power supply circuit board 17Bs Since the power supply circuit board 17Bs is fixed so as to be in thermal contact with the power supply heat dissipation area 15B, the heat generated in the power supply circuit section 17 can be efficiently transferred to the power supply heat dissipation area 15B. Then, the heat transferred to the heat radiation area 15B for power supply is also diffused and transferred to the side peripheral surface portion 11A of the motor housing 11 to be radiated to the outside.
- the heat transfer performance is further improved by interposing any one of an adhesive, a heat radiating grease, a heat radiating sheet or the like having good heat transfer between the power circuit board 17Bs and the power radiating area 15B.
- control circuit 18 is installed from the upper side of the power supply circuit section 17.
- the microcomputer and peripheral circuits constituting the control circuit section 18 are a control circuit board made of a glass epoxy board (corresponding to a second circuit board). It is mounted on 18Bs.
- the control circuit unit 18 also employs a dual system, and as is clear from the figure, control circuits each including a microcomputer and peripheral circuits are formed in line symmetry.
- the microcomputer and peripheral circuits may be provided on the surface of the control circuit board 18Bs on the power supply circuit 17 side.
- control circuit unit 18 is installed on the power supply circuit unit 17 in a laminated form.
- the control circuit unit 17 includes the power supply circuit board 17Bs of the power supply circuit unit 17 and the control circuit board 18Bs of the control circuit unit 18.
- the spaces are electrically connected by the flexible substrate 23. Therefore, the supply of control signals and electric power is exchanged via the flexible substrate 23.
- the power supply circuit board 17 and the control circuit board 18 may be connected using a board connecting connector.
- a spacer 24 having a predetermined length is interposed between the power circuit board 17Bs and the control circuit board 18Bs. That is, the power supply circuit board 17Bs and the control circuit board 18Bs are stacked in the axial direction of the motor housing 11, but tall electric components such as coils and capacitors are placed on the power supply circuit board 17Bs.
- the spacer 24 forms a storage space for storing electric parts such as coils and capacitors.
- the spacers 24 can be made of synthetic resin or metal, and if there are three or more spacers, a storage space can be formed, but in this embodiment, four spacers 24 are used.
- the spacer 24 has an annular shape (pipe shape) with both ends opened, and the shaft portion of the common fixing bolt penetrates the through hole 24H formed inside. Therefore, the spacer 24 is arranged at a position corresponding to the through hole 17H of the power supply circuit board 17Bs. Further, the diameter of the through hole 24H of the spacer 24 is formed to be larger than the diameter of the through hole 17H of the power supply circuit board 17Bs and the through hole 18H of the control circuit board 18Bs described later to facilitate penetration of the common fixing bolt. ..
- Through holes 18H corresponding to the positions of the bolt screw holes 21S formed in the board fixing portions 21A and 21B are formed at the four corners of the control circuit board 18Bs. Therefore, in the state where the power supply circuit board 17Bs and the control circuit board 18Bs are assembled and laminated, the through hole 18H of the control circuit board 18Bs, the through hole 24H of the spacer 24, the through hole 17H of the power circuit board 17Bs, and the board fixing portion 21A, Each of the bolt screw holes 21S of 21B is in a state of overlapping in the axial direction.
- the spacer 24 is drawn as a separate body from the power supply circuit board 17Bs and the control circuit board 18Bs, the spacer 24 may be fixed to the power supply circuit board 17Bs or the control circuit board 18Bs in advance.
- the spacer 24 can be simultaneously mounted by the solder.
- the power supply circuit board 17Bs and the control circuit board 18Bs may be fixed in advance.
- the connector assemblies 13 are installed in a stacked form from the upper side of the control circuit unit 18.
- the connector assembly 13 is formed with a bolt holding portion 13F extending toward the outer peripheral side in the radial direction orthogonal to the axial direction.
- Through holes 13H corresponding to the positions of the bolt screw holes 21S formed in the board fixing portions 21A and 21B are formed at the four corners of the bolt holding portion 13F.
- the power supply circuit board 17Bs, the control circuit board 18Bs, and the connector assembly 13 are assembled and stacked, the power supply circuit board is oriented in the axial direction of the motor housing 11 in the direction away from the end surface wall 15 of the motor housing 11. 17Bs, the spacer 24, the control circuit board 18Bs, and the connector assembly 13 are arranged in this order.
- the through hole 13H of the connector assembly 1, the through hole 18H of the control circuit board 18Bs, the through hole 24H of the spacer 24, the through hole 17H of the power supply circuit board 17Bs, and the bolt screw holes 21S of the board fixing portions 21A and 21B, respectively. are overlapped in the axial direction.
- the tips of the four common fixing bolts (fixing members) 25 having an elongated shape are inserted into the through holes 13H of the bolt holding portion 13F from the connector assembly 13 side, and the through holes of the control circuit board 18Bs are inserted.
- 18H, the through hole 24H of the spacer 24, and the through hole 17H of the power supply circuit board 17Bs are inserted in this order, and finally the threaded portion of each tip of each common fixing bolt 25 is fixed to the board.
- the parts are screwed into the screw holes 21S of the parts 21A and 21B and fixed. Therefore, the control circuit board 18Bs is pressed against the spacer 24 side by the connector assembly 13, and the power supply circuit board 17Bs is pressed against the board fixing portions 21A and 21B side by the spacer 24 to be fixed.
- the open end of the cap cover 12 is engaged with the end wall 15 of the motor housing 11 and fixed to each other by welding or adhesion.
- the power supply circuit board is fixed by the common fixing bolt, and the notch that matches the shape of the fixing boss that fixes the control circuit board as in Patent Document 1 is not formed. Similarly, the head receiving region of the fixing bolt screwed into the fixing boss for fixing the power circuit board to the fixing boss is not formed. Therefore, it is possible to increase the mounting area of the electronic components and electric components of the power supply circuit board located on the end wall side of the motor housing.
- Patent Document 1 since the control circuit board and the power supply circuit board are separately fixed to the fixing boss of the motor housing by the fixing bolts, eight fixing bolts are required. Since only four fixing bolts are required, the cost of parts of the product can be reduced, and further, the work of screwing the fixing bolts can be reduced, so that the manufacturing cost can be reduced.
- a power conversion circuit section 16 is fixed to the end surface wall 15 of the motor housing 11 in a form of close contact. Further, the power supply circuit board 17Bs is placed on the board fixing portions 21A and 21B on the upper side. Further, electric components and electronic components are mounted on the power supply circuit board 17Bs.
- a control circuit board 18Bs is arranged above the electric and electronic parts of the power supply circuit board 17Bs, and the control circuit board 18Bs is supported by the spacer 24.
- the through hole 18H of the control circuit board 18Bs and the through hole 24H of the spacer 24 are also fixed in an overlapping relationship.
- electronic components and electric components such as the microcomputer 28 and peripheral circuits thereof are mounted.
- the connector assembly 13 is arranged on the upper side of the electronic components and electric components of the control circuit board 18Bs, and the connector assembly 13 has a bolt holding portion 13F.
- the bolt holding portion 13F is placed on the upper side of the control circuit board 18Bs.
- a head housing portion 13C for housing the head of each common fixing bolt 25 is formed in the bolt holding portion 13F, and the common fixing bolt 25 is inserted into a through hole 13H formed in the bolt holding portion 13F. There is.
- each common fixing bolt 25 is inserted in the order of the through hole 18H of the control circuit board 18Bs, the through hole 24H of the spacer 24, and the through hole 17H of the power supply circuit board 17Bs, and finally each shaft portion 25R.
- the screw part at the tip of is fixed by screwing into the bolt screw hole 21S of the substrate fixing parts 21A and 21B.
- control circuit board 18Bs, the spacer 24, and the power supply circuit board 17Bs are sandwiched and firmly fixed between the bolt holding portion 13F of the connector assembly 13 and the board fixing portions 21A and 21B.
- the power supply circuit board 17Bs is fixed by the common fixing bolt 25, and it is not necessary to form a notch corresponding to the shape of the fixing boss that fixes the control circuit board 17Bs. Similarly, it is not necessary to form the head receiving region of the fixing bolt screwed into the fixing boss that fixes the power circuit board 17Bs. Therefore, it is possible to increase the mounting area of the electronic components and electric components of the power supply circuit board 17Bs located on the end wall 15 side of the motor housing.
- the cost of parts of the product can be reduced, and the screwing work of each common fixing bolt 25 can be reduced, so that the manufacturing cost can be reduced.
- the spacer 24 is divided into a first divided spacer and a second divided spacer, and the first divided spacer is a right cylindrical spacer body 24C having a through hole 24H, and the second divided spacer is , A spacer receiving portion 24R having a storage recess 24P in which one end of the spacer 24C is stored.
- the spacer receiving portion 24R is also provided with the through hole 24H.
- the spacer body 24C is soldered to the control circuit board 18Bs by a reflow process so as to overlap the through hole 18H of the control circuit board 18Bs, and the spacer receiving portion 24R is overlapped with the through hole 17H of the power circuit board 17Bs. Soldered to 17Bs by a reflow process.
- the spacer body 24C and the spacer receiving portion 24R can be fixed to the opposite circuit boards.
- One end of the right cylindrical spacer body 24C and the storage recess 24P are shaped so that they can be engaged with the spigot (inlay), so that when the spacer body 24C and the spacer receiving portion 24R are combined, they are respectively positioned. It has a shape that allows it.
- inlay engagement means that a member having a larger diameter is inserted into a member having a hole having a larger diameter, and the members are fitted and engaged with each other.
- the power conversion circuit section 16 is directly attached to the power conversion heat dissipation area 15A formed on the end wall 15 of the motor housing 11, but in the second embodiment, it is provided on the surface of the power conversion circuit board. The difference is that a power switching element and the like are mounted.
- first spacer 24 the spacer 24 of the first embodiment will be described as “first spacer 24”.
- At least three first and first elements which are arranged on the end wall of the motor housing on the side opposite to the output portion of the rotary shaft of the electric motor and mounted with circuit components for driving the electric motor, are provided.
- a second spacer which is interposed between the second spacer and has a predetermined length and is fixed to the end wall, and a connector assembly that is connected to each circuit board, and is separated from the end wall of the motor housing in the axial direction of the motor housing.
- the third circuit board, the second spacer, the second circuit board, the first spacer, the first circuit board, and the connector assembly are arranged in this order in this order, and the common fixing member is the connector. From the assembly side, the connector assembly, the first circuit board, the first spacer, and the through hole provided in the second circuit board are inserted and fixed to the second spacer.
- the third circuit board, the second spacer, the second circuit board, the first spacer, the first spacer, 1 circuit board and the connector assembly are arranged in this order, and the common fixing member is provided on the connector assembly, the first circuit board, the first spacer, and the second circuit board from the connector assembly side. Since it is inserted into the through hole and fixed to the second spacer, the mounting area of electronic components and electric components of the circuit boards positioned on the end face wall side of the motor housing among the circuit boards arranged in a stack Can be expanded.
- the power conversion circuit board (third circuit board) 16Bs made of a glass epoxy board is mounted with a power switching element 29 made of a MOSFET or an IGBT.
- the power switching element 29 is arranged on the side of the power supply circuit board 17Bs of the power conversion circuit board 16Bs, but it may be arranged on the opposite side. In this case, a storage space for the power switching element 29 may be provided in a part of the end wall 15.
- the power conversion circuit board 16Bs is arranged between the power supply circuit board 17Bs and the end wall 15 of the motor housing 11 via the second spacer 30.
- the second spacer 30 is determined to have a length capable of forming a storage space for storing the power switching element 29 and related components thereof, or the electric components and electronic components mounted on the power conversion circuit board 16Bs side of the power supply circuit board 17Bs. Has been.
- the second spacer 30 is driven into the screw forming portion 30S into which the screw portion at the tip of the common fixing bolt 25 is screwed and the fitting fixing hole 31 formed in the end face wall 15 to fix the fixing hole. 31 and a fitting fixing portion 30F that fits into the fitting 31.
- the formation position of the fitting fixing hole 31 is the same position as the position of the bolt screw hole 21S of the board fixing portions 21A and 21B described in the first embodiment.
- the fitting fixing portion 30F and the fitting fixing hole 31 can be changed to screw fixing.
- a fixed step portion 30N whose diameter increases from the fitting fixing portion 30F to the screw forming portion 30S is formed between the screw forming portion 30S and the fitting fixing portion 30F.
- the fixed step portion 30N is disposed between the end surface wall 15 and the power conversion circuit board 16Bs in a state where the fitting fixing portion 30F penetrates the through hole 16H formed in the power conversion circuit board 16Bs and is fixed to the fitting fixing hole 31. It is fixed by sandwiching it with.
- Each of the shaft portions 25R of the four common fixing bolts 25 has a through hole 13H of the connector assembly 13, a through hole 18H of the control circuit board 18Bs, a through hole 24H of the first spacer 24, and a power circuit board 17Bs.
- the through holes 17H are inserted in that order, and finally the threaded portion at the tip of the shaft portion 25R is screwed into and fixed to the thread forming portion 30S of the second spacer 30.
- control circuit board 18Bs is pressed against the first spacer 24 side by the connector assembly 13, and the power supply circuit board 17Bs is pressed against the second spacer 30 side by the first spacer 24 and fixed.
- control circuit board 18Bs, the first spacer 24, and the power supply circuit board 17Bs are pressed from both ends and are firmly fixed between the bolt holding portion of the connector assembly 13 and the second spacer 30.
- the power conversion circuit board 16Bs is fixed to the end wall 15 by the second spacer 30.
- first spacer 24 may be replaced with the spacer shown in FIG.
- the cost of parts of the product can be reduced, and the screwing work of the common fixing bolt 25 can be reduced, so that the manufacturing cost can be reduced.
- the second spacer 30 may be formed integrally with the end surface portion 15 of the motor housing 11.
- the power conversion circuit board 16Bs may be fixed to the end surface portion 15 with another fixing bolt, or may have the same structure as that of the first embodiment.
- At least two sheets of circuit components for driving the electric motor which are arranged on the side of the end surface wall of the motor housing opposite to the output portion of the rotary shaft of the electric motor, are mounted.
- the first and second circuit boards, spacers of a predetermined length interposed between the circuit boards, and a connector assembly that is connected to the circuit boards, respectively, are provided in the axial direction of the rotating shaft of the electric motor.
- the first circuit board, the spacer, the second circuit board, and the connector assembly in this order from the end surface wall of the motor housing, and the common fixing member from the connector assembly side to the connector assembly,
- the second circuit board, the spacer, and the through hole provided in the first circuit board are inserted and fixed to the end surface wall of the motor housing.
- At least three first members which are arranged on the side of the end face wall of the motor housing opposite to the output portion of the rotary shaft of the electric motor and mounted with circuit components for driving the electric motor, Second and third circuit boards, a first spacer having a predetermined length interposed between the first circuit board and the second circuit board, a second circuit board, and a third circuit board And a connector assembly connected to each circuit board, the second spacer being interposed between the second spacer and fixed to the end face wall, and the end of the motor housing in the axial direction of the rotating shaft of the electric motor.
- the third circuit board, the second spacer, the second circuit board, the first spacer, the first circuit board, and the connector assembly are arranged in this order, and the common fixing member is the connector assembly. From the side, the connector assembly, the first circuit board, the first spacer, and the through hole provided in the second circuit board are inserted and fixed to the second spacer.
- the present invention is not limited to the above-described embodiments, but includes various modifications.
- the above-described embodiments have been described in detail for the purpose of explaining the present invention in an easy-to-understand manner, and are not necessarily limited to those having all the configurations described.
- a part of the configuration of a certain embodiment can be replaced with the configuration of another embodiment, and the configuration of another embodiment can be added to the configuration of a certain embodiment.
- other configurations can be added/deleted/replaced.
Landscapes
- Engineering & Computer Science (AREA)
- Power Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Microelectronics & Electronic Packaging (AREA)
- Power Steering Mechanism (AREA)
- Motor Or Generator Frames (AREA)
Abstract
モータハウジング11の端面壁15の側に配置され、電動モータを駆動するための回路部品を実装した2枚の回路基板17、18と、夫々の回路基板の間に介装された所定長さのスペーサ24と、夫々の回路基板に接続されるコネクタ組立体13を備え、モータハウジングの軸線方向で、端面壁15から遠ざかる方向に向けて、第1回路基板17、スペーサ24、第2回路基板18、及びコネクタ組立体13の順番でこれらを配置し、共用固定部材25がコネクタ組立体13側から、コネクタ組立体13、第2回路基板18、スペーサ24、及び第1回路基板17を挿通して、端面壁15に固定されている。 積層して配置された回路基板で、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる。
Description
本発明は電動駆動装置に関し、特に電子制御装置を内蔵した電動駆動装置に関するものである。
一般的な産業機械分野においては、電動モータによって機械系制御要素を駆動することが行われているが、最近では電動モータの回転速度や回転トルクを制御する半導体素子等からなる電子制御部を電動モータに一体的に組み込む、いわゆる機電一体型の電動駆動装置が採用され始めている。
機電一体型の電動駆動装置の一例として、例えば自動車の電動パワーステアリング装置においては、運転者がステアリングホィールを操作することにより、回動するステアリングシャフトの回動方向と回動トルクとを検出し、この検出値に基づいてステアリングシャフトの回動方向と同じ方向へ回動するように電動モータを駆動して、操舵アシストトルクを発生させるように構成されている。この電動モータを制御するため、電子制御部(ECU:Electronic Control Unit)がパワーステアリング装置に設けられている。
従来の電動パワーステアリング装置としては、例えば、特開2018-125948号公報(特許文献1)に記載のものが知られている。特許文献1には、電動モータ部と電子制御部とにより構成された電動パワーステアリング装置が記載されている。
尚、この他に電子制御装置を一体化した電動駆動装置としては、電動ブレーキや各種油圧制御用の電動油圧制御器等が知られているが、以下の説明では代表して電動パワーステアリング装置について説明する。
特許文献1に記載の電動パワーステアリング装置において、制御回路基板と電源回路基板は、積層、配置されており、これらの回路基板は、それぞれ別々に固定ボルトによってモータハウジングの端面壁に固定されている。
尚、特許文献1では、電源回路基板が制御回路基板よりモータハウジングの端面壁側に寄せて配置されているが、制御回路基板が電源回路基板よりモータハウジングの端面壁側に寄せて配置されている場合も同様である。
このように、制御回路基板と電源回路基板を積層して配置し、それぞれの固定ボスに固定ボルトによって固定しているので、制御回路基板と電源回路基板が個別に固定されることで、各回路基板を固定するための固定用面積が大きくなり、電子部品や電気部品の実装面積が減少するという課題を有している。
本発明の目的は、積層して配置された回路基板で、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる新規な電動駆動装置を提供することにある。
本発明は、
機械系制御要素を駆動する電動モータが収納されたモータハウジングと、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも2枚の第1及び第2の回路基板と、それぞれの回路基板の間に介装された所定長さのスペーサと、それぞれの回路基板に接続されるコネクタ組立体を備え、
電動モータの回転軸の軸線方向にモータハウジングの前記端面壁から、第1の回路基板、スペーサ、第2の回路基板、及びコネクタ組立体の順番でこれらを配置し、
共用固定部材がコネクタ組立体の側から、コネクタ組立体、第2の回路基板、スペーサ、及び第1の回路基板に設けた貫通孔を挿通して、モータハウジングの端面壁に固定されていることを特徴としている。
また、本発明は、
機械系制御要素を駆動する電動モータが収納されたモータハウジングと、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも3枚の第1、第2、及び第3の回路基板と、第1の回路基板と第2の回路基板の間に介装された所定長さの第1のスペーサと、第2の回路基板と第3の回路基板の間に介装され、端面壁に固定された所定長さの第2のスペーサと、それぞれの回路基板に接続されるコネクタ組立体を備え、
電動モータの回転軸の軸線方向にモータハウジングの端面壁から、第3の回路基板、第2のスペーサ、第2の回路基板、第1のスペーサ、第1の回路基板、及びコネクタ組立体の順番でこれらを配置し、
共用固定部材がコネクタ組立体の側から、コネクタ組立体、第1の回路基板、第1のスペーサ、第2の回路基板に設けた貫通孔を挿通して、第2のスペーサに固定されている
ことを特徴としている。
本発明によれば、積層して配置された回路基板のうち、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる。
以下、本発明の実施形態について図面を用いて詳細に説明するが、本発明は以下の実施形態に限定されることなく、本発明の技術的な概念の中で種々の変形例や応用例をもその範囲に含むものである。
本発明の実施形態を説明する前に本発明が適用される一例としての操舵装置の構成について図1を用いて簡単に説明する。
まず、自動車の前輪を操舵するための操舵装置について説明する。操舵装置1は、図1に示すように構成されている。図示しないステアリングホイールに連結されたステアリングシャフト2の下端には図示しないピニオンが設けられ、このピニオンは車体左右方向へ長いラック(図示せず)と噛み合っている。
このラックの両端には前輪を左右方向へ操舵するためのタイロッド3が連結されており、ラックはラックハウジング4に覆われている。そして、ラックハウジング4とタイロッド3との間にはゴムブーツ5が設けられている。
ステアリングホイールを回動操作する際のトルクを補助するため、電動パワーステアリング装置6が設けられている。即ち、ステアリングシャフト2の回動方向と回動トルクとを検出するトルクセンサ7が設けられ、トルクセンサ7の検出値に基づいてラックにギヤ10を介して操舵補助力を付与する電動モータ部8と、電動モータ部8に配置された電動モータを制御する電子制御部9とが設けられている。
電動パワーステアリング装置6の電動モータ部8は、出力軸側の外周部の3箇所が図示しないボルトを介してギヤ10に接続され、電動モータ8部の出力軸とは反対側に電子制御部9が設けられている。
電動パワーステアリング装置6においては、ステアリングホイールが操作されることによりステアリングシャフト2がいずれかの方向へ回動操作されると、このステアリングシャフト2の回動方向と回動トルクとをトルクセンサ7が検出し、この検出値に基づいて電子制御部9の制御回路部が電動モータの駆動操作量を演算する。
この演算された駆動操作量に基づいて、電子制御部9の電力変換回路部のパワースイッチング素子により電動モータが駆動され、電動モータの出力軸はステアリングシャフト2の操作方向と同じ方向へ回転するように駆動される。出力軸の回動は、図示しないピニオンからギヤ10を介して図示しないラックへ伝達され、自動車が操舵される。これらの構成、作用は既によく知られているので、これ以上の説明は省略する。
ところで、最近の電動パワーステアリング装置等においては、サイバーセキュリティ対応やOTA(Over The Air)対応等が求められている。そして、サイバーセキュリティやOTAに対応するためには、更に追加の電子部品が必要とされ、電子部品の部品点数が増加することが予想される。一方で、電動パワーステアリング装置は、小型化も併せて求められている。したがって、これらの要求を満足するためには、電子制御部においては電子部品や電気部品を実装する回路基板の実装面積の拡大が必要となっている。
そして、特許文献1においては、制御回路基板と電源回路基板を積層、配置して固定ボルトによって固定ボスに固定する場合、モータハウジングの端面壁側に寄せて配置された回路基板は、他の回路基板の固定ボスの分だけ切り欠かれる形状となり、この分だけ電子部品や電気部品の実装面積が減少することになる。同様に、固定ボルトの頭部を受け止めるための頭部受け止め領域が必要となり、これも電子部品や電気部品の実装面積が減少することになる。したがって、積層して配置された回路基板で、モータハウジングの端面壁側に寄せた配置された回路基板の電子部品や電気部品の実装面積を拡大することが求められている。
このような背景から、本実施形態では次のような構成の電動パワーステアリング装置を提案するものである。
本実施形態においては、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも2枚の第1及び第2の回路基板と、それぞれの回路基板の間に介装された所定長さのスペーサと、それぞれ回路基板に接続されるコネクタ組立体とを備え、電動モータの回転軸の軸線方向にモータハウジングの前記端面壁から、第1の回路基板、スペーサ、第2の回路基板、及びコネクタ組立体の順番でこれらを配置し、共用固定部材がコネクタ組立体の側から、コネクタ組立体、第2の回路基板、スペーサ、及び第1の回路基板に設けた貫通孔を挿通して、モータハウジングの端面壁に固定されている構成とした。
このような構成によれば、電動モータの回転軸の軸線方向で、モータハウジングの端面壁から遠ざかる方向に向けて、第1の回路基板、スペーサ、第2の回路基板、及びコネクタ組立体の順番で配置し、共用固定部材が、コネクタ組立体の側から、コネクタ組立体、第2の回路基板、スペーサ、及び第1の回路基板に設けた貫通孔を挿通して、モータハウジングの端面壁に固定されているので、積層して配置された回路基板のうち、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる。
以下、本発明の一実施形態になる電動パワーステアリング装置の具体的な構成について、図2乃至図5を用いて詳細に説明する。尚、図2は本実施形態になる電動パワーステアリング装置の全体的な構成を示した図面であり、図3は図2に示す電動パワーステアリング装置の構成部品を分解して斜め方向から見た図面であり、図4はキャップカバーを取り外した電子制御部を側面から見た図面であり、図5は図4の電子制御部を斜め上方から見たす図面である。
図2に示すように、電動パワーステアリング装置6を構成する電動モータ部8は、アルミ合金等から作られた筒部を有するモータハウジング11と、これに収納された図示しない電動モータとから構成され、電子制御装置は、モータハウジング11の軸方向の出力軸14とは反対側に配置された、アルミ合金等で作られたキャップカバー12と、これに収納された電子制御部9とから構成されている。
モータハウジング11とキャップカバー12は、その対向端面で、接着剤、或いは溶着、或いは固定ボルトによって一体的に固定されている。キャップカバー12の内部の収納空間に収納された電子制御部9は、具体的に図示しないが、必要な電源を生成する電源回路部や、電動モータ部8の電動モータを駆動制御するMOSFET、或いはIGBT等からなるパワースイッチング素子を有する電力変換回路部や、このパワースイッチング素子を制御する制御回路部からなり、パワースイッチング素子の出力端子と電動モータのコイル入力端子とはバスバーを介して電気的に接続されている。
キャップカバー12の端面には、コネクタ組立体13が設けられている。コネクタ組立体13には、電力供給用のコネクタ端子形成部13A、検出センサ用のコネクタ端子形成部13B、制御状態を外部機器に送出する制御状態送出用のコネクタ端子形成部13Cを備えている。
そして、キャップカバー12に収納された電子制御部9は、合成樹脂から作られた電力供給用のコネクタ端子形成部13Aを介して電源から電力が供給され、また検出センサ類から運転状態等の検出信号が検出センサ用のコネクタ形成端子部13Bを介して供給され、現在の電動パワーステアリング装置の制御状態信号が制御状態送出用のコネクタ端子形成部13Cを介して送出されている。
図3に電動パワーステアリング装置6の分解斜視図を示している。モータハウジング11の内部には、円環状の鉄製のサイドヨーク(図示せず)が嵌合されており、このサイドヨーク内に電動モータ(図示せず)が収納されている。電動モータの出力部14はギヤを介してラックに操舵補助力を付与している。尚、電動モータの具体的な構造は良く知られているので、ここでは説明を省略する。
モータハウジング11はアルミ合金から作られており、電動モータで発生した熱や、後述する電源回路部や電力変換回路部で発生した熱を外部大気に放出するヒートシンク部材として機能している。電動モータとモータハウジング11で電動モータ部8を構成している。
電動モータ部8の出力部14の反対側には、モータハウジング11の端面壁15が形成されており、この端面壁15には、電子制御部9が取り付けられている。電子制御部9は、電力変換回路部16、電源回路部17、制御回路部18から構成されている。モータハウジング11の端面壁15はヒートシンクとして機能し、モータハウジング11と一体的に形成されているが、この他に端面壁15だけを別体に形成し、ボルトや溶接によってモータハウジング11と一体化しても良いものである。
ここで、電力変換回路部16と電源回路部17及び制御回路部18は冗長系を構成するものであり、主電子制御部と副電子制御部の二重系を構成している。そして、通常は主電子制御部によって電動モータが制御、駆動されているが、主電子制御部に異常や故障が生じると、副電子制御部に切り換えられて電動モータが制御、駆動される。
したがって、通常は主電子制御部からの熱がモータハウジング11に伝えられ、主電子制御部に異常や故障が生じると、主電子制御部が停止して副電子制御部が作動し、モータハウジング11には副電子制御部からの熱が伝えられる。
また、これとは別に、主電子制御部と副電子制御部を合せて正規の電子制御部として機能させ、一方の電子制御部に異常や故障が生じると、他方の電子制御部で半分以上の能力によって電動モータを制御、駆動することも可能である。
この場合、電動モータの能力は低減するが、いわゆる「パワーステアリング機能」は確保されるようになっている。したがって、通常の場合は、主電子制御部と副電子制御部の熱がモータハウジング11に伝えられるものである。
電子制御部9は、制御回路部18や電源回路部17、電力変換回路部16、及びコネクタ組立体13から構成されており、モータハウジング11の軸線方向で、端面壁15側から離れる方向に向かって、電力変換回路部16、電源回路部17、制御回路部18、コネクタ組立体13の順序で配置されている。
ここで、モータハウジングの軸線とは、モータハウジング11に収納される電動モータの回転軸の中心線にほぼ一致する軸線を意味するものであり、以下では、モータハウジングの軸線を単に軸線と表記する場合もある。
制御回路部18は電力変換回路部16のパワースイッチング素子を駆動する制御信号を生成するもので、マイクロコンピュータや周辺回路等から構成されている。電源回路部17は、制御回路部18の電源や電力変換回路部16の電源を生成するもので、コンデンサやコイル、パワースイッチング素子等から構成されている。電力変換回路部16は、電動モータのコイルに流れる電力を調整するもので、3相の上下アームを構成するパワースイッチング素子等から構成されている。
制御回路部18や電源回路部17を構成する電気部品や電子部品等の回路部品は、ガラスエポキシ基板からなる回路基板の表面上に実装されており、これらの回路基板は、電動モータの回転軸に直交する半径方向に配置されている。そして、制御回路部18や電源回路部17及び電力変換回路部16は、軸線方向に順番に積層される形態で配置されている。
電子制御部9で発熱量が多いのは、主に電力変換回路部16や電源回路部17であり、電力変換回路部16や電源回路部17の熱は、アルミ合金からなるモータハウジング11から放熱される。尚、本実施形態では、モータハウジング11の端面壁15に、電力変換回路部16が密着して取り付けられている。
電力変換回路部16は、弾発機能を有する固定部材20によって、端面壁15に密着して取り付けられる構成となっている。つまり、固定部材20に形成した弾発機能部材によって、電力変換回路部16をモータハウジング11の端面壁15側に形成した放熱部側に向けて押圧して、電力変換回路部16を放熱部に押圧、保持している。
制御回路部18とキャップカバー12の間には、合成樹脂からなるコネクタ組立体13が配置されており、車両バッテリ(電源)や、外部の図示しない他の制御装置と接続されている。もちろん、このコネクタ組立体13は、電力変換回路部16、電源回路部17、制御回路部18と適宜接続されていることはいうまでもない。
キャップカバー12は、電力変換回路部16と電源回路部17及び制御回路部18を収納してこれらを液密的に封止する機能を備えているものであり、本実施形態では溶着や接着によってモータハウジング11の端面壁15に固定されている。このキャップカバー12は金属で作られているので、電力変換回路部16や電源回路部17等によって発生した熱を外部に放熱する機能も併せ備えている。
キャップカバー12には、開口12Aが形成され、この開口12Aからコネクタ組立体13のコネクタ端子形成部13A~13Cが露出している。開口12Aは、孔縁部にコネクタ組立体13が密着し、この密着部分に0リング、或いは液状シール剤が配置されて液密化を図っている。
電動モータの出力部14とは反対側に位置する端面壁15の面には、電力変換回路部16や電源回路部17の放熱領域15A、15Bが形成されている。端面壁15の四隅には、同じ高さの基板固定部21A、21Bが一体的に形成されており、内部にボルトねじ穴21Sが形成されている。基板固定部21A、21Bは、電源回路部17の電源回路基板(第1の回路基板に相当)17Bsを載置するために設けられている。
ここで、基板固定部21Aは、電力変換用放熱領域15Aから植立して形成され、基板固定部21Bは、電源用放熱領域15Bに形成されている。電源用放熱領域15Bに形成された基板固定部21Bは、電源用放熱領域15Bを含めて基板固定部21Bとされている。
図3からわかるように、軸線と直交する半径方向の端面壁15を形成する平面領域は2分割されている。1つは電力変換回路部16が取り付けられる電力変換用放熱領域15Aを形成し、もう1つは電源回路部17が取り付けられる電源用放熱領域15Bを形成している。本実施形態では、電力変換用放熱領域15Aの方が電源用放熱領域15Bより面積が大きく形成されている。これは、上述したように二重系を採用しているため、電力変換回路部16の設置面積を確保するためである。
そして、電力変換用放熱領域15Aと電源用放熱領域15Bは、軸線方向において高さが異なる段差状になっている。つまり、電源用放熱領域15Bは、軸線方向で見て、電力変換用放熱領域15Aに対して離れる方向に段差状に突出形成されている。この段差は、電力変換回路部16を設置した後に、電源回路部17を設置した場合において、電力変換回路部16と電源回路部17がそれぞれ干渉しない長さに設定されている。
電力変換用放熱領域15Aには、3個の細長い矩形の突状放熱部22が形成されている。この突状放熱部22には、二重系の電力変換回路部16が設置される。突状放熱部22は、軸線方向で見て電動モータから離れる方向に突出して延びている。
また、電源用放熱領域15Bは平面状であって、電源回路部17の電源回路基板17Bsが設置される。更に、電源用放熱領域15Bには、電動モータの回転軸の中心側に向かって延びる延長放熱領域15Cが形成されている。これは、3個の電力変換回路部16が突状放熱部22に「コ」字状に載置された場合、電力変換回路部16が存在しない空間を、電源回路部17の放熱領域として利用するために形成されている。
したがって、突状放熱部22は、電力変換回路部16で発生した熱を端面壁15に伝熱する放熱部として機能し、電源用放熱領域15Bは、電源回路部17で発生した熱を端面壁15に伝熱する放熱部として機能する。尚、突状放熱部22は省略することができ、この場合は電力変換用放熱領域15Aが、電力変換回路部16で発生した熱を端面壁15に伝熱する放熱部として機能する。
このように、本実施形態になるモータハウジング11の端面壁15においては、ヒートシンク部材を省略できるので、軸方向の長さを短くできる。また、モータハウジング11は十分な熱容量を有しているので、電源回路部17や電力変換回路部16の熱を効率よく外部に放熱することができる。
次に、電力変換回路部16の上側から電源回路部17が設置されるが、この場合は電源用放熱領域15Bの上部に電源回路部17の電源回路基板17Bsが設置される。電源回路部17を構成するコンデンサやコイル等は、ガラスエポキシ基板からなる電源回路基板17Bsに実装されている。電源回路部17も二重系が採用されており、図からわかるように、それぞれ線対称の形態で、コンデンサやコイル等からなる電源回路が形成されている。
この電源回路基板17Bsの電源用放熱領域15B側の面は、電源用放熱領域15Bと接触するようにして端面壁15に固定されている。固定方法は、基板固定部21A、21Bに設けられたボルトねじ穴21Sに、「共用固定部材」として機能する細長い形状の「共用固定ボルト」(これについては後述する)をねじ込むことによって固定される。したがって、電源回路基板17Bsの四隅には、基板固定部21A、21Bのボルトねじ穴21Sの位置に対応した貫通孔17Hが形成されている。
ここで、電源回路基板17Bsを固定するのは、後述する共用固定ボルトであり、特許文献1にあるような、制御回路基板を固定する固定ボスの形状に合せた切り欠きが形成されていない。同様に、電源回路基板を固定ボスに固定するため、固定ボスにねじ込まれる固定ボルトの頭部受け領域も形成されていない。このため、モータハウジングの端面壁15側に位置する電源回路基板17Bsの電子部品や電気部品の実装面積を拡大することができる。
尚、電源回路部17の電源回路基板17Bsがガラスエポキシ基板で形成されているため、両面実装が可能となっている。そして、電源回路基板17Bsの電源用放熱領域15B側の面には、図示しないGMR素子や、これの検出回路等からなる回転位相、回転数検出部が実装され、電動モータの回転軸に設けた回転検出部と協働して、回転軸の回転位相や回転数を検出するようになっている。
電源回路基板17Bsは、電源用放熱領域15Bに熱的に接触するようにして固定されているので、電源回路部17で発生した熱を効率良く電源用放熱領域15Bに伝熱させることができる。そして、電源用放熱領域15Bに伝えられた熱は、モータハウジング11の側周面部11Aにも拡散、伝熱されて外部に放熱される。
ここで、電源回路基板17Bsと電源用放熱領域15Bの間は、熱伝達性の良い接着剤や放熱グリース、放熱シート等のいずれか1つを介在させることで、更に熱伝達性能を向上させることができる。
次に、電源回路部17の上側から制御回路18が設置されるが、制御回路部18を構成するマイクロコンピュータや周辺回路は、ガラスエポキシ基板からなる制御回路基板(第2の回路基板に相当)18Bsに実装されている。制御回路部18も二重系が採用されており、図から明らかなように、それぞれ線対称の形態で、マイクロコンピュータや周辺回路等からなる制御回路が形成されている。尚、マイクロコンピュータや周辺回路等は、制御回路基板18Bsの電源回路17側の面に設けられていても良い。
このように、電源回路部17の上部には、制御回路部18が積層される形態で設置されるが、電源回路部17の電源回路基板17Bsと、制御回路部18の制御回路基板18Bsとの間は、フレキシブル基板23によって電気的に接続されている。したがって、制御信号や電力の供給は、フレキシブル基板23を介してやり取りされる。尚、電源回路基板17と制御回路基板18の接続は、基板接続用コネクタを用いても良い。
更に、電源回路基板17Bsと制御回路基板18Bsの間には、所定長さのスペーサ24が介装されている。すなわち、電源回路基板17Bsと制御回路基板18Bsは、モータハウジング11の軸線方向に積層されるが、電源回路基板17Bsには、コイルやコンデンサ等の背の高い電気部品が載置されている。
このため、コイルやコンデンサ等の電気部品を収納するための収納空間をスペーサ24によって形成している。スペーサ24は、合成樹脂や金属でつくることができ、また3本以上であれば収納空間を形成できるが、本実施形態では4本のスペーサ24を使用している。
また、スペーサ24は、両端が開口した円環状(パイプ状)であり、内部に形成された貫通孔24Hを共用固定ボルトの軸部が貫通するものである。したがって、スペーサ24は、電源回路基板17Bsの貫通孔17Hに対応した位置に配置される。更に、スペーサ24の貫通孔24Hの直径は、電源回路基板17Bsの貫通孔17Hや後述する制御回路基板18Bsの貫通孔18Hの直径より大きく形成されており、共用固定ボルトを貫通し易くしている。
制御回路基板18Bsの四隅には、基板固定部21A、21Bに形成したボルトねじ穴21Sの位置に対応した貫通孔18Hが形成されている。したがって、電源回路基板17Bsと制御回路基板18Bsを組み上げて積層した状態では、制御回路基板18Bsの貫通孔18H、スペーサ24の貫通孔24H,電源回路基板17Bsの貫通孔17H、及び基板固定部21A、21Bのボルトねじ穴21Sのそれぞれは、軸線方向で重なった状態となる。
ここで、スペーサ24は、電源回路基板17Bsと制御回路基板18Bsとは別体に描かれているが、電源回路基板17Bs、或いは制御回路基板18Bsに予め固定する構成とすることも可能である。例えば、電源回路基板17Bs、或いは制御回路基板18Bsにリフロープロセスによって電子部品や電気部品をハンダによって実装する時に、同時にスペーサ24をハンダによって実装することができる。同様に、電源回路基板17Bsと制御回路基板18Bsに予め固定する構成とすることもできる。
次に、制御回路部18の上側からコネクタ組立体13が積層される形態で設置されている。コネクタ組立体13には、軸線方向に直交する半径方向で外周側に向けて延びるボルト保持部13Fが形成されている。このボルト保持部13Fの四隅には、基板固定部21A、21Bに形成したボルトねじ穴21Sの位置に対応した貫通孔13Hが形成されている。
したがって、電源回路基板17Bs、制御回路基板18Bs、及びコネクタ組立体13を組み上げて積層した状態では、モータハウジング11の軸線方向で、モータハウジング11の端面壁15から遠ざかる方向に向けて、電源回路基板17Bs、スペーサ24、制御回路基板18Bs、及びコネクタ組立体13の順番で配置されている。
そして、コネクタ組立体1の貫通孔13H,制御回路基板18Bsの貫通孔18H、スペーサ24の貫通孔24H、電源回路基板17Bsの貫通孔17H、及び基板固定部21A、21Bのボルトねじ穴21Sのそれぞれは、軸線方向で重なった状態となる。
この状態で、コネクタ組立体13の側から、ボルト保持部13Fの貫通孔13Hに細長い形状の4本の共用固定ボルト(固定部材)25のそれぞれの先端を挿入し、制御回路基板18Bsの貫通孔18H、スペーサ24の貫通孔24H、電源回路基板17Bsの貫通孔17Hの順にそれぞれの共用固定ボルト25を挿入していき、最終的に各共用固定ボルト25のそれぞれの先端のねじ部を、基板固定部21A、21Bのボルトねじ穴21Sにねじ込み固定する。したがって、コネクタ組立体13によって、制御回路基板18Bsはスペーサ24の側に押し付けられ、スペーサ24によって電源回路基板17Bsは基板固定部21A、21Bの側に押し付けられて固定される。
更にこの後に、キャップカバー12の開口端が、モータハウジング11の端面壁15に係合され、溶着或いは接着によって相互に固定されている。
このように、電源回路基板を固定するのは共用固定ボルトであり、特許文献1にあるような、制御回路基板を固定する固定ボスの形状に合せた切り欠きが形成されていない。同様に、電源回路基板を固定ボスに固定するための固定ボスにねじ込まれる固定ボルトの頭部受け領域も形成されていない。このため、モータハウジングの端面壁側に位置する電源回路基板の電子部品や電気部品の実装面積を拡大することができる。
更に、特許文献1においては、制御回路基板と電源回路基板は、それぞれ別々に固定ボルトによってモータハウジングの固定ボスに固定されているので、8本の固定ボルトが必要となるが、本実施形態では4本の固定ボルトで良いので、製品の部品コストを低減でき、更には固定ボルトのねじ止め作業も少なくできるので、製造コストも低減できる。
次に、組み上げられた電子制御部9の構成について図4、及び図5を用いて説明する。モータハウジング11の端面壁15には、電力変換回路部16が密着する形態で固定されている。更に、この上側で電源回路基板17Bsが基板固定部21A、21Bに載置されている。また、電源回路基板17Bsには電気部品や電子部品が実装されている。
電気部品であるコイル26やコンデンサ27は背(軸線方向での高さ)が高いので、これの収納空間が必要である。このため、電源回路基板17Bsの貫通孔17Hの上には、スペーサ24がリフロープロセスによってハンダ付けされている。また当然であるが、電源回路基板17Bsの貫通孔17Hとスペーサ24の貫通孔24Hとは重なり合う関係で固定されている。
更に、電源回路基板17Bsの電気部品や電子部品の上側には、制御回路基板18Bsが配置され、この制御回路基板18Bsはスペーサ24によって支えられている。この制御回路基板18Bsの貫通孔18Hとスペーサ24の貫通孔24Hも重なり合う関係で固定されている。制御回路基板18Bsには、マイクロコンピュータ28やこれの周辺回路等の電子部品や電気部品が実装されている。
更に、制御回路基板18Bsの電子部品や電気部品の上側には、コネクタ組立体13が配置され、このコネクタ組立体13には、ボルト保持部13Fが形成されている。このボルト保持部13Fは、制御回路基板18Bsの上側に載置されている。ボルト保持部13Fには、各共用固定ボルト25の頭部を収納する頭部収納部13Cが形成されており、共用固定ボルト25が、ボルト保持部13Fに形成された貫通孔13Hに挿入されている。
各共用固定ボルト25の軸部25Rは、それぞれ制御回路基板18Bsの貫通孔18H、スペーサ24の貫通孔24H、電源回路基板17Bsの貫通孔17Hの順に挿入されていき、最終的に各軸部25Rの先端のねじ部を、基板固定部21A、21Bのボルトねじ穴21Sにねじ込み固定する。
これによって、コネクタ組立体13のボルト保持部13Fと基板固定部21A、21Bとの間で、制御回路基板18Bs、スペーサ24、及び電源回路基板17Bsが両端から挟まれて強固に固定される。
このように、電源回路基板17Bsを固定するのは、共用固定ボルト25であり、制御回路基板17Bsを固定する固定ボスの形状に合せた切り欠きを形成する必要がなくなる。同様に、電源回路基板17Bsを固定する固定ボスにねじ込まれる固定ボルトの頭部受け領域も形成する必要がなくなる。このため、モータハウジングの端面壁15側に位置する電源回路基板17Bsの電子部品や電気部品の実装面積を拡大することができる。
更に、本実施形態では4本の共用固定ボルト25で良いので、製品の部品コストを低減でき、更には各共用固定ボルト25のねじ止め作業も少なくできるので、製造コストも低減できる。
次に、スペーサ24の変形例について図6を用いて説明する。図6において、スペーサ24は、第1分割スペーサと第2分割スペーサに二分割されており、第1分割スペーサは、貫通孔24Hを備える直円筒状のスペーサ本体24Cであり、第2分割スペーサは、スペーサ24Cの一端が収納される収納凹部24Pを有するスペーサ受部24Rである。もちろん、スペーサ受部24Rにも貫通孔24Hが設けられている。
スペーサ本体24Cは、制御回路基板18Bsの貫通孔18Hに重なるように制御回路基板18Bsにリフロープロセスによってハンダで固着され、スペーサ受部24Rは電源回路基板17Bsの貫通孔17Hに重なるように電源回路基板17Bsにリフロープロセスによってハンダで固着されている。尚、スペーサ本体24Cとスペーサ受部24Rは、それぞれ反対の回路基板に固着することもできる。
直円筒状のスペーサ本体24Cの一端と収納凹部24Pは、印籠(インロー)係合できるような形状に決められており、これによって、スペーサ本体24Cとスペーサ受部24Rを組み合わせた時に、それぞれが位置決めできる形状とされている。
ここで、印籠(インロー)係合とは、直径が大きい孔を有した部材に、これよりも直径が小さい部材を挿入して嵌め合い係合させるものを意味している。
したがって、スペーサ24の貫通孔24Hと、電源回路基板17Bsの貫通孔17Hと、制御回路基板18Bsの貫通孔18Hの位置整合性を高めることができ、更には、組み付け性を向上させることができる。
次に、本発明の第2の実施形態について説明する。第1の実施形態では電力変換回路部16は、モータハウジング11の端面壁15に形成した電力変換用放熱領域15Aに直付けされているが、第2の実施形態では電力変換回路基板の表面にパワースイッチング素子等が実装されている点で異なっている。
このため、電力変換回路基板のパワースイッチング素子の収納空間を形成し、しかも電力変換回路基板を端面部に固定する第2スペーサが新たに設けられている。尚、これに合せて本実施形態では、第1の実施形態のスペーサ24は「第1のスペーサ24」として説明する。
本実施形態においては、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも3枚の第1、第2、及び第3の回路基板と、第1の回路基板と第2の回路基板の間に介装された所定長さの第1のスペーサと、第2の回路基板と第3の回路基板の間に介装され、端面壁に固定された所定長さの第2のスペーサと、それぞれの回路基板に接続されるコネクタ組立体を備え、モータハウジングの軸線方向で、モータハウジングの端面壁から遠ざかる方向に向けて、第3の回路基板、第2のスペーサ、第2の回路基板、第1のスペーサ、第1の回路基板、及びコネクタ組立体の順番でこれらを配置し、共用固定部材がコネクタ組立体の側から、コネクタ組立体、第1の回路基板、第1のスペーサ、第2の回路基板に設けた貫通孔を挿通して、第2のスペーサに固定されている構成とした。
このような構成によれば、モータハウジングの軸線方向で、モータハウジングの端面壁から遠ざかる方向に向けて、第3の回路基板、第2のスペーサ、第2の回路基板、第1のスペーサ、第1の回路基板、及びコネクタ組立体の順番でこれらを配置し、共用固定部材がコネクタ組立体の側から、コネクタ組立体、第1の回路基板、第1のスペーサ、第2の回路基板に設けた貫通孔を挿通して、第2のスペーサに固定されているので、積層して配置された回路基板のうち、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる。
以下、第2の実施形態を説明するが、第1の実施形態と同じ参照番号は、同じ構成要件を示しているので説明は省略する。
図7~図9において、ガラスエポキシ基板からなる電力変換回路基板(第3の回路基板)16Bsには、MOSFET、或いはIGBTからなるパワースイッチング素子29が実装されている。このパワースイッチング素子29は、電力変換回路基板16Bsの電源回路基板17Bsの側に配置されているが、これとは反対側に配置することもできる。この場合は、端面壁15の一部にパワースイッチング素子29の収納空間を設ければ良い。
電力変換回路基板16Bsは、電源回路基板17Bsとモータハウジング11の端面壁15との間に、第2スペーサ30を介して配置されている。第2スペーサ30は、パワースイッチング素子29及びこれの関連部品、或いは電源回路基板17Bsの電力変換回路基板16Bsの側に実装された電気部品や電子部品を収納する収納空間を形成できる長さに決められている。
図8に示しているように、第2スペーサ30は、共用固定ボルト25の先端のねじ部がねじ込まれるねじ形成部30Sと、端面壁15に形成した嵌合固定穴31に打ち込まれ、固定穴31に嵌合する嵌合固定部30Fとから構成されている。嵌合固定穴31の形成位置は、第1の実施形態で説明した基板固定部21A、21Bのボルトねじ孔21Sの位置と等しい位置である。尚、嵌合固定部30Fと嵌合固定穴31は、ねじ固定に変更することも可能である。
ねじ形成部30Sと嵌合固定部30Fの間には、嵌合固定部30Fからねじ形成部30Sに直径が拡大する固定段部30Nが形成されている。固定段部30Nは、嵌合固定部30Fが電力変換回路基板16Bsに形成した貫通孔16Hを貫通して嵌合固定穴31に固定された状態で、電力変換回路基板16Bsを端面壁15の間で挟み込んで固定している。
したがって、電力変換回路基板16Bsと、電源回路基板17Bsと、制御回路基板18Bs及びコネクタ組立体13を組み上げて積層した状態では、モータハウジング11の軸線方向で、モータハウジング11の端面壁15から遠ざかる方向に向けて、電力変換回路基板16Bs、第2スペーサ30、電源回路基板17Bs、第1スペーサ24、制御回路基板18Bs、及びコネクタ組立体13の順番で配置されている。
そして、4本の共用固定ボルト25のそれぞれの軸部25Rは、コネクタ組立体13の貫通孔13Hと、制御回路基板18Bsの貫通孔18H、第1スペーサ24の貫通孔24H、電源回路基板17Bsの貫通孔17Hの順に挿入されていき、最終的に軸部25Rの先端のねじ部を、第2スペーサ30のねじ形成部30Sにねじ込み固定する。
したがって、コネクタ組立体13によって、制御回路基板18Bsは第1スペーサ24の側に押し付けられ、第1スペーサ24によって電源回路基板17Bsは第2スペーサ30の側に押し付けられて固定される。これによって、コネクタ組立体13のボルト保持部と13Fと第2スペーサ30との間で、制御回路基板18Bs、第1スペーサ24、及び電源回路基板17Bsが両端から押圧されて強固に固定される。また、電力変換回路基板16Bsは、第2スペーサ30によって端面壁15に固定される。
尚、本実施形態においても、第1のスペーサ24は図6に示すスペーサに置き換えて良いことはいうまでもない。
このように、第2の実施形態においても、電源回路基板17Bsを固定するのは、共用固定ボルト25であり、制御回路基板17Bsを固定する固定ボスの形状に合せた切り欠きを形成する必要がなくなる。同様に、電源回路基板17Bsを固定する固定ボスにねじ込まれる固定ボルトの頭部受け領域も形成する必要がなくなる。このため、モータハウジングの端面壁15側に位置する電源回路基板17Bsの電子部品や電気部品の実装面積を拡大することができる。
更に、本実施形態では4本の共用固定ボルト25で良いので、製品の部品コストを低減でき、更には共用固定ボルト25のねじ止め作業も少なくできるので、製造コストも低減できる。
ここで、第2スペーサ30は、モータハウジング11の端面部15に一体的に形成することもできる。ただ、この場合においては、電力変換回路基板16Bsは別の固定ボルトで端面部15に固定する、或いは実施例1と同様の構成とするといった構成を採用すれば良い。
以上述べた通り、本発明においては、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも2枚の第1及び第2の回路基板と、それぞれの回路基板の間に介装された所定長さのスペーサと、及びそれぞれ回路基板に接続されるコネクタ組立体を備え、電動モータの回転軸の軸線方向にモータハウジングの端面壁から、第1の回路基板、スペーサ、第2の回路基板、及びコネクタ組立体の順番でこれらを配置し、共用固定部材がコネクタ組立体の側から、コネクタ組立体、第2の回路基板、スペーサ、及び第1の回路基板に設けた貫通孔を挿通して、モータハウジングの端面壁に固定されている構成とした。
また、本発明においては、電動モータの回転軸の出力部とは反対側のモータハウジングの端面壁の側に配置され、電動モータを駆動するための回路部品を実装した少なくとも3枚の第1、第2、及び第3の回路基板と、第1の回路基板と第2の回路基板の間に介装された所定長さの第1のスペーサと、第2の回路基板と第3の回路基板の間に介装され、端面壁に固定された所定長さの第2のスペーサと、それぞれの回路基板に接続されるコネクタ組立体を備え、電動モータの回転軸の軸線方向にモータハウジングの端面壁から、第3の回路基板、第2のスペーサ、第2の回路基板、第1のスペーサ、第1の回路基板、及びコネクタ組立体の順番でこれらを配置し、共用固定部材がコネクタ組立体の側から、コネクタ組立体、第1の回路基板、第1のスペーサ、第2の回路基板に設けた貫通孔を挿通して、第2のスペーサに固定されている構成とした。
本発明によれば、積層して配置された回路基板のうち、モータハウジングの端面壁側に位置する回路基板の電子部品や電気部品の実装面積を拡大することができる。
尚、本発明は、上記した実施例に限定されるものではなく、様々な変形例が含まれる。例えば、上記した実施例は本発明を分かりやすく説明するために詳細に説明したものであり、必ずしも説明した全ての構成を備えるものに限定されるものではない。また、ある実施例の構成の一部を他の実施例の構成に置き換えることが可能であり、また、ある実施例の構成に他の実施例の構成を加えることも可能である。また、各実施例の構成の一部について、他の構成の追加・削除・置換をすることが可能である。
6…電動パワーステアリング装置、8…電動モータ部、9…電子制御部、11…モータハウジング、12…キャップカバー、13…コネクタ組立体、13F…ボルト保持部、13H…貫通孔、14…出力部、15…端面壁、16…電力変換回路部、17…電源回路部、17Bs…電源回路基板、17H…貫通孔、18…制御回路部、18Bs…制御回路基板、18H…貫通孔、21A、21B…基板固定部、21S…ボルトねじ孔、24…スペーサ、24H…貫通孔、25…共用固定ボルト。
Claims (16)
- 機械系制御要素を駆動する電動モータが収納されたモータハウジングと、
前記電動モータの回転軸の出力部とは反対側の前記モータハウジングの端面壁の側に配置され、前記電動モータを駆動するための回路部品を実装した少なくとも2枚の第1及び第2の回路基板と、
それぞれの前記回路基板の間に介装された所定長さのスペーサと、
それぞれの前記回路基板に接続されるコネクタ組立体と、
を備え、
前記電動モータの回転軸の軸線方向に前記モータハウジングの前記端面壁から、前記第1の回路基板、前記スペーサ、前記第2の回路基板、及び前記コネクタ組立体の順番でこれらを配置し、
共用固定部材が前記コネクタ組立体の側から、前記コネクタ組立体、前記第2の回路基板、前記スペーサ、及び前記第1の回路基板に設けた貫通孔を挿通して、前記モータハウジングの前記端面壁に固定されていることを特徴とする電動駆動装置。 - 請求項1に記載の電動駆動装置において、
前記スペーサは、前記第1の回路基板、或いは前記第2の回路基板にハンダによって固着されていることを特徴とする電動駆動装置。 - 請求項2に記載の電動駆動装置において、
前記スペーサと前記回路部品とは、前記第1の回路基板、或いは前記第2の回路基板にリフロープロセスによってハンダ付けされていることを特徴とする電動駆動装置。 - 請求項2に記載の電動駆動装置において、
前記スペーサに設けた前記貫通孔の直径は、前記第1の回路基板、及び前記第2の回路基板に設けた前記貫通孔の直径より大きく形成されていることを特徴とする電動駆動装置。 - 請求項1に記載の電動駆動装置において、
前記スペーサは、第1分割スペーサ、及び第2分割スペーサに二分割され、前記第1分割スペーサは前記第1の回路基板にハンダによって固着され、前記第2分割スペーサは前記第2の回路基板にハンダによって固着され、前記第1分割スペーサ、及び前記第2分割スペーサは、それぞれを組み合せた時に位置決めされる形状を有していることを特徴とする電動駆動装置。 - 請求項5に記載の電動駆動装置において、
前記第1分割スペーサ、及び前記第2分割スペーサは、それぞれが印籠係合されて位置決めされることを特徴とする電動駆動装置。 - 請求項1に記載の電動駆動装置において、
前記第2の回路基板は、前記電動モータを駆動する電力変換回路を制御する制御回路が設けられた制御回路基板であり、
前記第1の回路基板は、前記電力変換回路を及び前記制御回路の電源を生成する電源回路が設けられた電源回路基板であることを特徴とする電動駆動装置。 - 機械系制御要素を駆動する電動モータが収納されたモータハウジングと、
前記電動モータの回転軸の出力部とは反対側の前記モータハウジングの端面壁の側に配置され、前記電動モータを駆動するための回路部品を実装した少なくとも3枚の第1、第2、及び第3の回路基板と、
第1の回路基板と第2の回路基板の間に介装された所定長さの第1のスペーサと、
前記第2の回路基板と第3の回路基板の間に介装され、前記端面壁に固定された所定長さの第2のスペーサと、
それぞれの前記回路基板に接続されるコネクタ組立体と、を備え、
前記電動モータの回転軸の軸線方向に前記モータハウジングの前記端面壁から、前記第3の回路基板、前記第2のスペーサ、前記第2の回路基板、前記第1のスペーサ、前記第1の回路基板、及び前記コネクタ組立体の順番でこれらを配置し、
共用固定部材が前記コネクタ組立体の側から、前記コネクタ組立体、前記第1の回路基板、前記第1のスペーサ、前記第2の回路基板に設けた貫通孔を挿通して、前記第2のスペーサに固定されていることを特徴とする電動駆動装置。 - 請求項8に記載の電動駆動装置において、
前記第1のスペーサは、前記第1の回路基板、或いは前記第2の回路基板にハンダによって固着されていることを特徴とする電動駆動装置。 - 請求項9に記載の電動駆動装置において、
前記第1のスペーサは、前記第1の回路基板、或いは前記第2の回路基板に前記回路部品と共にリフロープロセスによってハンダ付けされていることを特徴とする電動駆動装置。 - 請求項9に記載の電動駆動装置において、
前記第1のスペーサに設けた前記貫通孔の直径は、前記第1の回路基板、及び前記第2の回路基板に設けた前記貫通孔の直径より大きく形成されていることを特徴とする電動駆動装置。 - 請求項8に記載の電動駆動装置において、
前記第1のスペーサは、第1分割スペーサ、及び第2分割スペーサに二分割され、前記第1分割スペーサは前記第1の回路基板にハンダによって固着され、前記第2分割スペーサは前記第2の回路基板にハンダによって固着され、前記第1分割スペーサ、及び前記第2分割スペーサは、それぞれを組み合せた時に位置決めされる形状を有していることを特徴とする電動駆動装置。 - 請求項8に記載の電動駆動装置において、
前記第3の回路基板は、前記第2のスペーサと前記端面壁の間にはさまれて介装されていることを特徴とする電動駆動装置。 - 請求項13に記載の電動駆動装置において、
前記共用固定部材は、少なくとも先端にねじを備えた固定ボルトであり、前記固定ボルトのねじは、前記第2のスペーサに形成されたねじ部にねじ込まれて、前記コネクタ組立体、前記第1の回路基板、前記第1のスペーサ、及び前記第2の回路基板を挟み込んで固定することを特徴とする電動駆動装置。 - 請求項14に記載の電動駆動装置において、
前記第2のスペーサは、前記第3の回路基板に設けた貫通孔を貫通して前記端面壁に形成した嵌合固定穴に嵌合する嵌合固定部を備えていることを特徴とする電動駆動装置。 - 請求項8に記載の電動駆動装置において、
前記第3の回路基板は、前記電動モータを駆動する電力変換回路が設けられた電力変換回路基板であり、
前記第1の回路基板は、前記電動モータを駆動する電力変換回路を制御する制御回路が設けられた制御回路基板であり、
前記第2の回路基板は、前記電力変換回路を及び前記制御回路の電源を生成する電源回路が設けられた電源回路基板であることを特徴とする電動駆動装置。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019019575A JP7182486B2 (ja) | 2019-02-06 | 2019-02-06 | 電動駆動装置 |
| JP2019-019575 | 2019-02-06 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020162530A1 true WO2020162530A1 (ja) | 2020-08-13 |
Family
ID=71947628
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/004506 Ceased WO2020162530A1 (ja) | 2019-02-06 | 2020-02-06 | 電動駆動装置 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP7182486B2 (ja) |
| WO (1) | WO2020162530A1 (ja) |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2023136247A1 (ja) * | 2022-01-11 | 2023-07-20 | 株式会社デンソー | 駆動装置 |
| EP4096065A4 (en) * | 2021-02-10 | 2023-08-30 | NSK Ltd. | Electric drive device and electric power steering device |
| US11909274B2 (en) | 2021-02-10 | 2024-02-20 | Nsk Ltd. | Electric driving device, electric power steering device, and method for manufacturing electronic control unit |
| US12512731B2 (en) | 2021-02-10 | 2025-12-30 | Nsk Ltd. | Electric driving device and electric power steering device |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7518922B2 (ja) * | 2020-12-28 | 2024-07-18 | 日立Astemo株式会社 | 電子制御装置 |
| JP7827075B2 (ja) * | 2021-12-28 | 2026-03-10 | 株式会社ジェイテクト | モータユニット |
| EP4597806A4 (en) | 2022-09-29 | 2025-10-22 | Mitsubishi Electric Mobility Corp | ROTATING ELECTRIC MACHINE AND ITS MANUFACTURING METHOD |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH1140914A (ja) * | 1997-07-23 | 1999-02-12 | Sharp Corp | 基板連結構造 |
| JP2012028487A (ja) * | 2010-07-22 | 2012-02-09 | Panasonic Corp | 樹脂封止基板装置と、それらの製造方法 |
| JP2012209414A (ja) * | 2011-03-29 | 2012-10-25 | Mitsubishi Heavy Ind Ltd | 電子基板およびこれを搭載したインバータ一体型電動圧縮機 |
| JP2017221072A (ja) * | 2016-06-10 | 2017-12-14 | 日本電産サンキョー株式会社 | モータ |
| JP2018046591A (ja) * | 2016-09-12 | 2018-03-22 | 日立オートモティブシステムズ株式会社 | 電動駆動装置及び電動パワーステアリング装置 |
-
2019
- 2019-02-06 JP JP2019019575A patent/JP7182486B2/ja active Active
-
2020
- 2020-02-06 WO PCT/JP2020/004506 patent/WO2020162530A1/ja not_active Ceased
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH1140914A (ja) * | 1997-07-23 | 1999-02-12 | Sharp Corp | 基板連結構造 |
| JP2012028487A (ja) * | 2010-07-22 | 2012-02-09 | Panasonic Corp | 樹脂封止基板装置と、それらの製造方法 |
| JP2012209414A (ja) * | 2011-03-29 | 2012-10-25 | Mitsubishi Heavy Ind Ltd | 電子基板およびこれを搭載したインバータ一体型電動圧縮機 |
| JP2017221072A (ja) * | 2016-06-10 | 2017-12-14 | 日本電産サンキョー株式会社 | モータ |
| JP2018046591A (ja) * | 2016-09-12 | 2018-03-22 | 日立オートモティブシステムズ株式会社 | 電動駆動装置及び電動パワーステアリング装置 |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP4096065A4 (en) * | 2021-02-10 | 2023-08-30 | NSK Ltd. | Electric drive device and electric power steering device |
| US11909274B2 (en) | 2021-02-10 | 2024-02-20 | Nsk Ltd. | Electric driving device, electric power steering device, and method for manufacturing electronic control unit |
| US12142972B2 (en) | 2021-02-10 | 2024-11-12 | Nsk Ltd. | Electric driving device and electric power steering device |
| US12512731B2 (en) | 2021-02-10 | 2025-12-30 | Nsk Ltd. | Electric driving device and electric power steering device |
| WO2023136247A1 (ja) * | 2022-01-11 | 2023-07-20 | 株式会社デンソー | 駆動装置 |
| JP2023102157A (ja) * | 2022-01-11 | 2023-07-24 | 株式会社デンソー | 駆動装置 |
| JP7700682B2 (ja) | 2022-01-11 | 2025-07-01 | 株式会社デンソー | 駆動装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7182486B2 (ja) | 2022-12-02 |
| JP2020127334A (ja) | 2020-08-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7182486B2 (ja) | 電動駆動装置 | |
| US11870326B2 (en) | Electric drive apparatus, and electric power steering apparatus | |
| KR102097928B1 (ko) | 전동 구동 장치 및 전동 파워 스티어링 장치 | |
| WO2017154498A1 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| JP6879870B2 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| JP6723201B2 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| US20210139070A1 (en) | Electric driving device and electric power steering device | |
| WO2019082522A1 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| JP2017159772A (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| WO2021033678A1 (ja) | 電動駆動装置及び電動駆動装置の組立方法 | |
| CN109964392A (zh) | 电动驱动装置以及电动动力转向装置 | |
| JP7063747B2 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| US12088170B2 (en) | Electric drive device and electric power steering device with air circulation passage | |
| JP6864029B2 (ja) | 電動駆動装置 | |
| JP6909689B2 (ja) | 電動駆動装置及び電動パワーステアリング装置 | |
| US11715989B2 (en) | Electronic control device and electric drive device | |
| JP2020028165A (ja) | 電動駆動装置、及び電動パワーステアリング装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20752382 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20752382 Country of ref document: EP Kind code of ref document: A1 |