CN103600814A - Framed full-autonomous marine environment monitoring buoy - Google Patents
Framed full-autonomous marine environment monitoring buoy Download PDFInfo
- Publication number
- CN103600814A CN103600814A CN201310548580.3A CN201310548580A CN103600814A CN 103600814 A CN103600814 A CN 103600814A CN 201310548580 A CN201310548580 A CN 201310548580A CN 103600814 A CN103600814 A CN 103600814A
- Authority
- CN
- China
- Prior art keywords
- frame
- panel
- floating body
- type
- control center
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Landscapes
- Testing Or Calibration Of Command Recording Devices (AREA)
- Position Fixing By Use Of Radio Waves (AREA)
Abstract
本发明公开一种框架式全自主海洋环境监测浮标,海面上方的浮体底部通过框架式支柱垂直连接海面之下的框架式底座,浮体上部设有卫星天线、风向传感器、风速传感器、太阳能电池板;浮体内腔中设有集控中心、一对啮合齿轮、蓄电池、GPS模块、配电板、发电机和集线器;浮体正下方的三个测量面板位于海面位置且沿圆周方向均布并连接齿轮轴下部分,齿轮轴上端伸进浮体内并连接一对啮合齿轮,一对啮合齿轮连接发电机;在每个测量面板上都布置有分布式的波浪测量传感器;框架式底座中心部位设有储备浮力舱,框架式底座外的四周均匀布置四个螺旋桨;有效减小浮体受波浪的影响,实现全天候作业和高精度定点测量,具有优良的稳性和自扶正功能。

The invention discloses a frame-type fully autonomous marine environment monitoring buoy. The bottom of the floating body above the sea surface is vertically connected to the frame-type base below the sea surface through a frame-type pillar, and the upper part of the floating body is equipped with a satellite antenna, a wind direction sensor, a wind speed sensor, and a solar panel; There is a central control center, a pair of meshing gears, a battery, a GPS module, a switchboard, a generator and a hub in the cavity of the floating body; the three measurement panels directly below the floating body are located on the sea surface and are evenly distributed along the circumferential direction and connected to the gear shaft In the lower part, the upper end of the gear shaft extends into the floating body and connects a pair of meshing gears, which are connected to the generator; distributed wave measurement sensors are arranged on each measurement panel; the center of the frame base is equipped with a reserve buoyancy In the cabin, four propellers are evenly arranged around the frame base; effectively reducing the impact of waves on the floating body, realizing all-weather operation and high-precision fixed-point measurement, with excellent stability and self-righting function.
Description
技术领域 technical field
本发明涉及海洋环境监测技术领域,特别涉及一种能自主控制的适用于深海远海的海洋环境监测浮标。 The invention relates to the technical field of marine environment monitoring, in particular to an autonomously controlled marine environment monitoring buoy suitable for deep sea and open sea.
背景技术 Background technique
随着海洋技术的发展和人们对海洋资源的不断开发,对海浪参数的监测就显得尤为重要。目前,对近海岸、中远程海浪的监测多采用测波浮标,测波浮标由锚系系统固定于海底,在海上通过传感器采集数据,然后把采集到的数据传送到岸上,在岸上用计算机对数据进行处理,反演海洋参数。这种测波浮标存在的缺陷是:一是由于以锚定方式固定,使得其在深海远海的测量受到很大的限制,不适用于深海和距离海岸太远的区域,二是由于受到波浪力作用,很难做到高精度的定点观测;三是安装运输困难,可利用率低,回收困难。 With the development of marine technology and the continuous development of marine resources, the monitoring of wave parameters is particularly important. At present, wave measuring buoys are mostly used to monitor near-coast and mid-to-long-distance waves. Wave measuring buoys are fixed on the seabed by mooring systems, collect data through sensors at sea, and then transmit the collected data to the shore. The data are processed to invert oceanic parameters. The defects of this kind of wave measuring buoy are: firstly, because it is fixed by anchoring, its measurement in deep sea and open sea is greatly restricted, and it is not suitable for deep sea and areas that are too far from the coast; It is difficult to achieve high-precision fixed-point observation; third, it is difficult to install and transport, the availability rate is low, and it is difficult to recycle.
发明内容 Contents of the invention
本发明的目的是提供一种新型的框架式全自主海洋环境监测浮标,该浮标既适用于近海观测,又可应用到深海远海的定点海洋环境监测,能高精度的定点观测,实现可拆卸、运输方便、高效、自主、全天候作业的功能。 The purpose of the present invention is to provide a new type of frame-type fully autonomous marine environment monitoring buoy, which is not only suitable for offshore observation, but also can be applied to fixed-point marine environment monitoring in deep sea and far sea. The functions of convenient transportation, high efficiency, autonomy and all-weather operation. the
本发明通过以下技术方案予以实现:包括位于海面上方的浮体,浮体为密封的中空结构,浮体底部通过框架式支柱垂直连接位于海面之下的框架式底座,浮体上部设有卫星天线、风向传感器、风速传感器、太阳能电池板;浮体内腔中设有集控中心、一对啮合齿轮、蓄电池、GPS模块、配电板、发电机和集线器;浮体正下方设有三个测量面板和齿轮轴,三个测量面板位于海面的位置且沿圆周方向均布并连接于齿轮轴下部分,齿轮轴上端伸进浮体内部并连接一对啮合齿轮,一对啮合齿轮同时连接发电机;在每个测量面板上都布置有分布式的波浪测量传感器;在框架式底座中心部位设有储备浮力舱,在框架式底座外的四周均匀布置有四个螺旋桨,每个螺旋桨均相应地连接一个主机;太阳能电池板和发电机分别电连接蓄电池,蓄电池通过配电板分别电连接集控中心、GPS模块、主机、风向传感器、风速传感器;波浪测量传感器、GPS模块、主机、风向传感器、风速传感器均通过集线器连接集控中心,集控中心通过卫星天线将数据发送到岸基控制中心。 The present invention is realized through the following technical solutions: comprising a floating body above the sea surface, the floating body is a sealed hollow structure, the bottom of the floating body is vertically connected to the frame-type base below the sea surface through a frame-type pillar, and the upper part of the floating body is provided with a satellite antenna, a wind direction sensor, Wind speed sensor, solar panel; there are centralized control center, a pair of meshing gears, battery, GPS module, distribution board, generator and hub in the cavity of the floating body; there are three measuring panels and gear shafts directly below the floating body, three The measurement panels are located on the sea surface and are evenly distributed along the circumference and connected to the lower part of the gear shaft. The upper end of the gear shaft extends into the floating body and connects to a pair of meshing gears. A pair of meshing gears are connected to the generator at the same time; on each measurement panel Distributed wave measurement sensors are arranged; a reserve buoyancy chamber is arranged in the center of the frame base, and four propellers are evenly arranged around the outside of the frame base, and each propeller is correspondingly connected to a main engine; solar panels and power generation The machines are electrically connected to the battery respectively, and the battery is electrically connected to the centralized control center, GPS module, host, wind direction sensor, and wind speed sensor through the distribution board; the wave measurement sensor, GPS module, host, wind direction sensor, and wind speed sensor are all connected to the centralized control center through a hub , the centralized control center sends the data to the shore-based control center through the satellite antenna.
本发明与现有测波浮标相比,具有以下优点: Compared with the existing wave measuring buoy, the present invention has the following advantages:
1、本发明不仅可利用浮体上面的太阳能电池板采集太阳能,而且还可利用三块测量面板与发电机采集波浪能,能有效地克服目前常规锚定式浮标工作区域受限和工作效率低的缺点,实现全天候作业。 1. The present invention can not only use the solar panels on the floating body to collect solar energy, but also use three measuring panels and generators to collect wave energy, which can effectively overcome the shortcomings of the current conventional anchored buoys with limited working area and low working efficiency , to achieve round-the-clock operation.
2、本发明基于波浪理论相关知识,波浪的强度是随着水深成快速下降,基本在0.5倍波长的深度区域波浪强度基本为零,因此框架式支柱的长度为当地平均波长的0.5倍,此时框架式底座处于平静的水域,能够有效地减小浮体受波浪的影响。 2. The present invention is based on the relevant knowledge of wave theory. The intensity of waves decreases rapidly with the depth of water, and the intensity of waves in the depth region of 0.5 times the wavelength is basically zero. Therefore, the length of the frame-type pillars is 0.5 times the local average wavelength. When the frame base is in calm waters, it can effectively reduce the influence of waves on the floating body.
3、本发明的框架式底座上布置的四个螺旋桨可根据实时的GPS坐标进行调整,以实现浮标的高精度定点测量。 3. The four propellers arranged on the frame base of the present invention can be adjusted according to real-time GPS coordinates to realize high-precision fixed-point measurement of buoys.
4、本发明大部分的重量集中在浮体,为了提高其稳性,框架式底座的总重应该能够使整个浮标重心低于其浮心,从而使浮标具有优良的稳性,具有自扶正功能。 4. Most of the weight of the present invention is concentrated on the floating body. In order to improve its stability, the total weight of the frame base should make the center of gravity of the entire buoy lower than its buoyancy center, so that the buoy has excellent stability and self-righting function.
5、本发明的框架式底座中部设置储备浮力舱,提供整个浮标所需的浮力。 5. A reserve buoyancy chamber is provided in the middle of the frame base of the present invention to provide the required buoyancy for the entire buoy.
6、通过合理选择框架式支柱高度和对框架式底座上螺旋桨的实时控制,可实现浮标的定点测量。 6. The fixed-point measurement of the buoy can be realized by rationally selecting the height of the frame-type pillar and real-time control of the propeller on the frame-type base.
7、框架式支柱中的面板和框架式底座可有效的增强其耐波性能,具有自扶正功能。 7. The panel and frame base in the frame pillar can effectively enhance its seakeeping performance and have self-righting function.
8、本发明采用框架式结构,具有可拆卸性,运输方便,回收利用率高。既可应用于深海远海的海洋环境监测,也可应用于近海湖泊的水文观测。 8. The present invention adopts a frame structure, which is detachable, convenient for transportation and high in recycling rate. It can be applied not only to the monitoring of marine environment in the deep sea and far sea, but also to the hydrological observation of offshore lakes.
附图说明 Description of drawings
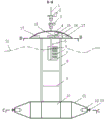
图1是本发明的主视图; Fig. 1 is the front view of the present invention;
图2是图1的俯视图; Fig. 2 is the top view of Fig. 1;
图3是图2中A-A视图; Fig. 3 is A-A view among Fig. 2;
图4是图1的B-B视图; Fig. 4 is the B-B view of Fig. 1;
图5是图3的C-C视图; Fig. 5 is the C-C view of Fig. 3;
图6是图3的D-D视图; Fig. 6 is the D-D view of Fig. 3;
图7是本发明的电路结构示意图; Fig. 7 is a schematic diagram of the circuit structure of the present invention;
1—卫星天线,2—风向传感器,3—风速传感器,4—浮体,5—齿轮轴,6—波浪测量传感器,7—测量面板,8—框架式支柱,9—面板,10—储备浮力舱,11—框架式底座,12—主机,13—螺旋桨,14—太阳能电池板,15—发电机,16—GPS模块,17—蓄电池,18—一对啮合齿轮,19—集控中心,20—集线器,21—配电板,22—海面。 1—satellite antenna, 2—wind direction sensor, 3—wind speed sensor, 4—floating body, 5—gear shaft, 6—wave measurement sensor, 7—measurement panel, 8—frame pillar, 9—panel, 10—reserve buoyancy chamber , 11—frame base, 12—main engine, 13—propeller, 14—solar panel, 15—generator, 16—GPS module, 17—battery, 18—a pair of meshing gears, 19—centralized control center, 20— Hub, 21—distribution board, 22—sea surface.
具体实施方式 Detailed ways
参见图1-6,本发明包括位于海面22上方的浮体4,浮体4为密封的中空结构,纵剖面为弓形或改良弓形,浮体4底部通过框架式支柱8,连接框架式底座11,框架式底座11位于海面22之下,框架式支柱8,与框架式底座11和浮体4均垂直连接。框架式支柱8和框架式底座11是采用轻质材料(例如:碳纤维复合材料,铝合金等)的骨架与外板制成的板架结构。
Referring to Figures 1-6, the present invention includes a
浮体4上部布置有卫星天线1、风向传感器2、风速传感器3、太阳能电池板14等设备,浮体4内腔中设置有集控中心19、一对啮合齿轮18、蓄电池17、GPS模块16、配电板21、发电机12和集线器20等设备。
框架式支柱8下部直接于框架式底座11连接在一起,框架式支柱8由多个模块单元上下叠加组成,每个模块单元由面板9和连接面板9的四个立柱组成,各模块单元之间通过螺栓或法兰等可拆卸连接结构连接组成。
The lower part of the frame-
浮体4的正下方安装三个测量面板7和齿轮轴5,测量面板7为一平板或对称翼型,三个测量面板7位于海面22的位置,三个测量面板7沿圆周方向均布且连接于齿轮轴5的下部分,两个测量面板7之间的夹角为120°,齿轮轴5的上端伸进浮体4内部,连接一对啮合齿轮18,一对啮合齿轮18同时连接发电机15,一对啮合齿轮18的减速比为1:5-10。在每个测量面板7上都布置用于测量波浪等海洋环境信息的分布式的波浪测量传感器6,并通过卫星进行数据传递。
Three
框架式底座11主要由轻质圆管相互连接组成,横剖视图近似圆形,其重量应该能够使整个浮标重心低于其浮心,从而使浮标具有优良的稳性,具有自扶正功能。框架式底座11中心部位设有储备浮力舱10,以保持浮标处于正常的吃水范围,用力提供整个浮标所需的浮力。框架式底座11外的四周均匀布置四个螺旋桨13,每个螺旋桨13均通过框架上的面板与相应的主机12连接,四个主机12均采用一体式防水电机,且位于框架式底座11与框架式底座11固定连接。所有内部多余空间全部采用小重度浮力材料填充,大幅度地提高了破损时的抗沉性,为在破损条件下,维持工作能力提供了支撑。
The
参见图7,太阳能电池板14和发电机12分别电连接蓄电池17,蓄电池17通过配电板21分别电连接集控中心19、GPS模块16、主机12、风向传感器2、风速传感器3等,向各设备供电,同时波浪测量传感器6、GPS模块16、主机12、风向传感器2、风速传感器3等产生的反馈或测量的数据通过集线器20输入到集控中心19,集控中心19对收到的数据进行分析、处理、保存,集控中心19同时利用卫星天线1将数据发送到岸基控制中心。
Referring to Fig. 7, the
本发明由利用浮体4上面的太阳能电池板14采集太阳能,利用测量面板7与发电机15采集波浪能,共同给蓄电池17充电,实现了全天候作业。基于波浪理论相关知识,波浪的强度是随着水深成快速下降,基本在0.5波长的深度区域波浪强度基本为零,框架式支柱8在高度方向的上下长度为测量海域平均波长的0.5-2倍,此时框架式底座11处于平静的水域,能够有效的减小其受波浪的影响。框架式底座11上布置的四个螺旋桨13可根据实际需要,实时的调整浮标位置,从而实现高精度定点观测。将GPS模块16提供的实时位置坐标与岸基控制中心提供的需要测量海区的经纬度信息对比,当出现位置偏移时,通过控制四个螺旋桨13的旋转从而使浮标恢复到预定位置,实现自主定位,高精度定点测量。
The present invention collects solar energy by utilizing the
Claims (4)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310548580.3A CN103600814B (en) | 2013-11-08 | 2013-11-08 | The complete autonomous marine environmental monitoring buoy of a kind of frame-type |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201310548580.3A CN103600814B (en) | 2013-11-08 | 2013-11-08 | The complete autonomous marine environmental monitoring buoy of a kind of frame-type |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN103600814A true CN103600814A (en) | 2014-02-26 |
| CN103600814B CN103600814B (en) | 2016-01-13 |
Family
ID=50119107
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201310548580.3A Expired - Fee Related CN103600814B (en) | 2013-11-08 | 2013-11-08 | The complete autonomous marine environmental monitoring buoy of a kind of frame-type |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN103600814B (en) |
Cited By (20)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103935472A (en) * | 2014-05-10 | 2014-07-23 | 中国石油大学(华东) | Dynamic positioning type ocean buoy |
| CN103935471A (en) * | 2014-04-12 | 2014-07-23 | 哈尔滨工程大学 | Buoyancy adjustor of propeller-propelling-type underwater buoy with telescopic cylinders |
| CN104260836A (en) * | 2014-10-11 | 2015-01-07 | 东南大学 | Water area surveillance robot for collecting water area information and control method thereof |
| CN104627324A (en) * | 2015-02-16 | 2015-05-20 | 交通运输部水运科学研究院 | Overwater auto-lift apparatus for fixing beacon light |
| CN105346692A (en) * | 2015-12-10 | 2016-02-24 | 山东大学 | Multi-energy complementary power supply ocean observing device |
| CN105799868A (en) * | 2016-05-29 | 2016-07-27 | 上海海洋大学 | Wave energy self-powered positioning type lifting ecobuoy |
| CN105908688A (en) * | 2016-04-12 | 2016-08-31 | 上海理工大学 | Steady buoy working platform |
| CN106301170A (en) * | 2015-05-27 | 2017-01-04 | 苏信吉 | Offshore mobile device and offshore power generation system thereof |
| CN106405042A (en) * | 2016-12-22 | 2017-02-15 | 重庆市科学技术研究院 | Water quality monitoring floating device for water environment, and monitoring system for water environment |
| WO2017162087A1 (en) * | 2016-03-22 | 2017-09-28 | 中电科海洋信息技术研究院有限公司 | Floating observation system |
| CN107554701A (en) * | 2017-08-11 | 2018-01-09 | 广州翔曦能源科技有限公司 | A kind of wave-activated power generation buoy |
| CN108917821A (en) * | 2018-03-17 | 2018-11-30 | 鲁东大学 | A kind of marine eco-environment monitoring system |
| CN109131749A (en) * | 2018-08-29 | 2019-01-04 | 国家海洋局第二海洋研究所 | A kind of long-range real-time control formula oceanographic buoy of self-propulsion type |
| CN110320560A (en) * | 2019-07-09 | 2019-10-11 | 浙江大学 | A kind of offshore earthquake and tsunami real-time monitoring system |
| CN110803256A (en) * | 2019-12-13 | 2020-02-18 | 江苏科技大学 | Movable multifunctional buoy with bottom |
| CN111724579A (en) * | 2020-07-01 | 2020-09-29 | 林立 | Buoy marine environment parameter automatic acquisition system based on LoRa technology |
| CN113291411A (en) * | 2021-05-27 | 2021-08-24 | 浙江海洋大学 | Automatic positioning ocean buoy based on Beidou communication |
| CN113525592A (en) * | 2021-06-10 | 2021-10-22 | 中国科学院海洋研究所 | A environmental data gathers and transmission device for marine ranch |
| CN114791507A (en) * | 2022-04-19 | 2022-07-26 | 河海大学 | An offshore wind measuring device |
| CN116902141A (en) * | 2023-07-12 | 2023-10-20 | 国家海洋局南海调查技术中心(国家海洋局南海浮标中心) | Deep sea condition monitoring system and buoy based on space satellite |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| NO344121B1 (en) * | 2018-04-26 | 2019-09-09 | Dronebuoy As | A geographical self-positioning buoy |
Citations (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4314575A1 (en) * | 1993-04-28 | 1994-11-03 | Bernt Dipl Ing Geerken | Fluid-driven buoy with independent power supply |
| CN1382905A (en) * | 2001-04-20 | 2002-12-04 | 成哲基 | Buoy having waveforce self-generating unit and waveforce generating method |
| KR20090015263A (en) * | 2007-08-08 | 2009-02-12 | 한국해양대학교 산학협력단 | Hybrid Power Generation and Management System for Buoys Using Photovoltaic, Wind, and Wave Power |
| WO2012172141A1 (en) * | 2011-06-13 | 2012-12-20 | Consejo Superior De Investigaciones Científicas (Csic) | Device for remotely tracking bodies of water and method for remotely and simultaneously managing and operating a set of said devices |
| CN202686698U (en) * | 2012-02-29 | 2013-01-23 | 巢湖市银环航标有限公司 | Large-scale marine meteorological monitoring buoy |
| CN103241343A (en) * | 2012-02-02 | 2013-08-14 | 营口临潼维宁科技有限公司 | Intelligent self-driven remote-control and remote-measuring solar buoy |
| CN103318381A (en) * | 2013-07-02 | 2013-09-25 | 大连海事大学 | An autonomous mobile monitoring buoy and its monitoring method |
| CN203272007U (en) * | 2013-05-13 | 2013-11-06 | 段鹏翔 | Novel wave power generation buoy |
-
2013
- 2013-11-08 CN CN201310548580.3A patent/CN103600814B/en not_active Expired - Fee Related
Patent Citations (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4314575A1 (en) * | 1993-04-28 | 1994-11-03 | Bernt Dipl Ing Geerken | Fluid-driven buoy with independent power supply |
| CN1382905A (en) * | 2001-04-20 | 2002-12-04 | 成哲基 | Buoy having waveforce self-generating unit and waveforce generating method |
| KR20090015263A (en) * | 2007-08-08 | 2009-02-12 | 한국해양대학교 산학협력단 | Hybrid Power Generation and Management System for Buoys Using Photovoltaic, Wind, and Wave Power |
| WO2012172141A1 (en) * | 2011-06-13 | 2012-12-20 | Consejo Superior De Investigaciones Científicas (Csic) | Device for remotely tracking bodies of water and method for remotely and simultaneously managing and operating a set of said devices |
| CN103241343A (en) * | 2012-02-02 | 2013-08-14 | 营口临潼维宁科技有限公司 | Intelligent self-driven remote-control and remote-measuring solar buoy |
| CN202686698U (en) * | 2012-02-29 | 2013-01-23 | 巢湖市银环航标有限公司 | Large-scale marine meteorological monitoring buoy |
| CN203272007U (en) * | 2013-05-13 | 2013-11-06 | 段鹏翔 | Novel wave power generation buoy |
| CN103318381A (en) * | 2013-07-02 | 2013-09-25 | 大连海事大学 | An autonomous mobile monitoring buoy and its monitoring method |
Cited By (26)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103935471A (en) * | 2014-04-12 | 2014-07-23 | 哈尔滨工程大学 | Buoyancy adjustor of propeller-propelling-type underwater buoy with telescopic cylinders |
| CN103935472A (en) * | 2014-05-10 | 2014-07-23 | 中国石油大学(华东) | Dynamic positioning type ocean buoy |
| CN104260836A (en) * | 2014-10-11 | 2015-01-07 | 东南大学 | Water area surveillance robot for collecting water area information and control method thereof |
| CN104627324A (en) * | 2015-02-16 | 2015-05-20 | 交通运输部水运科学研究院 | Overwater auto-lift apparatus for fixing beacon light |
| TWI628111B (en) * | 2015-05-27 | 2018-07-01 | 蘇信吉 | Marine mobile device and marine power generating system thereof |
| CN106301170A (en) * | 2015-05-27 | 2017-01-04 | 苏信吉 | Offshore mobile device and offshore power generation system thereof |
| CN106301170B (en) * | 2015-05-27 | 2019-05-24 | 苏信吉 | Offshore mobile device and offshore power generation system thereof |
| CN105346692A (en) * | 2015-12-10 | 2016-02-24 | 山东大学 | Multi-energy complementary power supply ocean observing device |
| US11584481B2 (en) | 2016-03-22 | 2023-02-21 | Cetc Ocean Information Co., Ltd. | Floating observation system |
| WO2017162087A1 (en) * | 2016-03-22 | 2017-09-28 | 中电科海洋信息技术研究院有限公司 | Floating observation system |
| CN105908688A (en) * | 2016-04-12 | 2016-08-31 | 上海理工大学 | Steady buoy working platform |
| CN105908688B (en) * | 2016-04-12 | 2018-01-26 | 上海理工大学 | Stable buoy working platform |
| CN105799868A (en) * | 2016-05-29 | 2016-07-27 | 上海海洋大学 | Wave energy self-powered positioning type lifting ecobuoy |
| CN106405042A (en) * | 2016-12-22 | 2017-02-15 | 重庆市科学技术研究院 | Water quality monitoring floating device for water environment, and monitoring system for water environment |
| CN107554701A (en) * | 2017-08-11 | 2018-01-09 | 广州翔曦能源科技有限公司 | A kind of wave-activated power generation buoy |
| CN108917821A (en) * | 2018-03-17 | 2018-11-30 | 鲁东大学 | A kind of marine eco-environment monitoring system |
| CN109131749A (en) * | 2018-08-29 | 2019-01-04 | 国家海洋局第二海洋研究所 | A kind of long-range real-time control formula oceanographic buoy of self-propulsion type |
| CN110320560A (en) * | 2019-07-09 | 2019-10-11 | 浙江大学 | A kind of offshore earthquake and tsunami real-time monitoring system |
| CN110803256A (en) * | 2019-12-13 | 2020-02-18 | 江苏科技大学 | Movable multifunctional buoy with bottom |
| CN110803256B (en) * | 2019-12-13 | 2024-05-24 | 江苏科技大学 | A bottom-mounted movable multifunctional buoy |
| CN111724579A (en) * | 2020-07-01 | 2020-09-29 | 林立 | Buoy marine environment parameter automatic acquisition system based on LoRa technology |
| CN113291411A (en) * | 2021-05-27 | 2021-08-24 | 浙江海洋大学 | Automatic positioning ocean buoy based on Beidou communication |
| CN113291411B (en) * | 2021-05-27 | 2022-06-03 | 浙江海洋大学 | An automatic positioning marine buoy based on Beidou communication |
| CN113525592A (en) * | 2021-06-10 | 2021-10-22 | 中国科学院海洋研究所 | A environmental data gathers and transmission device for marine ranch |
| CN114791507A (en) * | 2022-04-19 | 2022-07-26 | 河海大学 | An offshore wind measuring device |
| CN116902141A (en) * | 2023-07-12 | 2023-10-20 | 国家海洋局南海调查技术中心(国家海洋局南海浮标中心) | Deep sea condition monitoring system and buoy based on space satellite |
Also Published As
| Publication number | Publication date |
|---|---|
| CN103600814B (en) | 2016-01-13 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN103600814B (en) | The complete autonomous marine environmental monitoring buoy of a kind of frame-type | |
| CN103612723B (en) | The complete autonomous marine environmental monitoring buoy in a kind of far-reaching sea | |
| CN105857527B (en) | Laser radar surveys wind buoyage on three body combined type seas | |
| CN107917039B (en) | A fully enclosed inertial point-suction wave energy device | |
| CN103147903A (en) | Sea observation platform for unmanned and automatic navigation | |
| CN103910053A (en) | Unmanned observation control ship and unmanned observation control system | |
| CN106428495A (en) | Marine unmanned vehicle directly driven by wind energy | |
| CN104816796A (en) | High-performance small-waterline-area twin-body intelligent measurement ship | |
| CN105197180A (en) | Small multifunctional solar twin-hull unmanned ship | |
| CN107878682A (en) | Multi-functional based on green energy resource can dive Large marine buoy | |
| CN108248764A (en) | Buoy and its method of work are energized using the power generation of ocean wave energy and solar energy | |
| CN109185027B (en) | Vortex-induced vibration power generation unit, module and offshore comprehensive power generation device | |
| CN108001626A (en) | A kind of wave-energy power generation energy supply buoy and method based on piezoelectric effect | |
| CN105346692A (en) | Multi-energy complementary power supply ocean observing device | |
| CN205652288U (en) | Marine laser radar anemometry buoyage of trisome combination formula | |
| CN114320723A (en) | Water surveying and mapping device for surveying and mapping ocean engineering | |
| CN115123474A (en) | A safe buoy platform for parking unmanned aerial vehicle | |
| CN107600341A (en) | Four-column column-stabilized multi-purpose floating platform | |
| CN203864985U (en) | Unmanned measurement and control ship and unmanned measurement and control system | |
| CN106005265B (en) | A kind of top layer following sea stream confession electric multi parameter collects buoy | |
| CN207860395U (en) | Buoy is energized using the power generation of ocean wave energy and solar energy | |
| CN104875870A (en) | Ocean exploring robot driven by wave energy | |
| CN107618630A (en) | Single steady formula of column post uses floating platform | |
| CN204659979U (en) | A kind of energy-saving miniature self-service instrumentation ship | |
| CN107893732A (en) | A kind of removable float type marine energy TRT |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20160113 Termination date: 20181108 |