WO2024018682A1 - 車両制御装置 - Google Patents
車両制御装置 Download PDFInfo
- Publication number
- WO2024018682A1 WO2024018682A1 PCT/JP2023/008872 JP2023008872W WO2024018682A1 WO 2024018682 A1 WO2024018682 A1 WO 2024018682A1 JP 2023008872 W JP2023008872 W JP 2023008872W WO 2024018682 A1 WO2024018682 A1 WO 2024018682A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- vehicle
- information
- control device
- moving object
- vehicle control
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images




Classifications
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
- G08G1/166—Anti-collision systems for active traffic, e.g. moving vehicles, pedestrians, bikes
Definitions
- the present invention relates to a vehicle control device.
- Conventional vehicle control devices use the detection results of objects in front of the host vehicle to determine the possibility of a collision between the object and the host vehicle, and determine if there is a high possibility of a collision between the object in front of the host vehicle and the host vehicle.
- a vehicle control device that, if determined, performs collision avoidance control to avoid a collision with this object.
- the detection area changes as the vehicle's orientation changes, and if an object located in the blind spot enters the detection area, at the time the object is detected.
- the self-vehicle A technology for making the activation timing of the collision avoidance control earlier than when it is determined that the vehicle has not passed the object and when it is determined that the vehicle will not turn right or left after it has been determined that the vehicle has passed the object. has been proposed (see Patent Document 1).
- an object is detected by an external world recognition sensor such as a camera sensor attached to the vehicle, and tracking is performed for a certain period of time to determine and specify whether the object is to be avoided. Then, the flow of performing avoidance control on the avoidance target is followed.
- an external world recognition sensor such as a camera sensor attached to the vehicle
- tracking is performed for a certain period of time to determine and specify whether the object is to be avoided. Then, the flow of performing avoidance control on the avoidance target is followed.
- a certain period of tracking processing time is required to prevent misrecognition.
- avoidance control for an object coming from a cross direction
- avoidance control for an object coming from behind since the position where avoidance control is started is far from the host vehicle, it is easy to secure control margin time for avoidance.
- avoidance control for an object coming from behind the position at which avoidance control is started is close to the host vehicle, so it is difficult to secure control margin time for avoidance.
- the own vehicle since the own vehicle also moves, it is more difficult to secure sufficient control time for avoidance control against objects coming from behind. In this way, whether or not avoidance control can be performed in time depends on the direction in which the object approaches the own vehicle (see FIG. 1).
- the collision avoidance control proposed in the method of Patent Document 1 is to respond to an object located in a blind spot by determining it as an object to be avoided and then advancing the activation timing based on additional conditions. It does not take into account the time it takes to make a decision. Therefore, even if Patent Document 1 is applied, if a fast moving object such as a bicycle is coming from behind, it will take time to determine it as an object to be avoided, so even if the activation timing is advanced, a collision may occur. There is a high possibility that it cannot be avoided.
- the present invention has been made in view of the above circumstances, and an object of the present invention is to provide a vehicle control device that can secure a control margin necessary for avoidance control and perform collision avoidance control.
- a vehicle control device includes: an external world recognition section that acquires external world information at least in front of the own vehicle; a control section that controls the own vehicle based on the external world information acquired by the external world recognition section; a storage unit that stores detection information of the moving body acquired by the external world recognition unit when the vehicle overtakes the mobile body, and the external world recognition unit is configured to: The past detection information of the moving body stored in the storage unit is read, the possibility of a collision between the own vehicle and the moving body is determined, and based on the collision possibility, the own vehicle is stopped when changing the course of the own vehicle.
- a moving object that is likely to collide with a vehicle is set as predictive recognition information
- detection information of a moving object detected by the external world recognition unit when the host vehicle changes course is set as predictive recognition information of the mobile object that is included in the predictive recognition information. It is characterized by determining whether or not it is the same as past detection information.
- FIG. 2 is a schematic diagram of the problem used to explain the problem to be solved by the present invention.
- 1 is a schematic diagram of an embodiment of the invention.
- 1 is a schematic block diagram of a vehicle control device in an embodiment of the present invention.
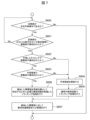
- 1 is an overall flowchart in an embodiment of the present invention.
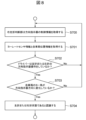
- 5 is a flowchart regarding collision possibility determination in an embodiment of the present invention.
- 5 is a flowchart regarding prediction area setting in an embodiment of the present invention.
- 5 is a flowchart regarding shortening of tracking processing using predictive recognition information in an embodiment of the present invention.
- 1 is a flowchart regarding right/left turn determination in an embodiment of the present invention.
- FIG. 1 shows a situation in which a vehicle makes a left turn at an intersection, in which a host vehicle 50 with an avoidance control function runs on a general road 55 having an intersection, a sensor detection area 51 used for the avoidance control function, and a sensor detection area 51 that performs avoidance control.
- avoidance control is performed for both a bicycle 52 coming from across the intersection and a bicycle 53 coming from behind.
- the avoidance control function prevents a collision by actually performing avoidance control after an obstacle is detected in the sensor detection area 51 and identified as an object to be avoided.
- the avoidance control is actually started after the bicycle 52 enters the sensor detection area 51 and is specified as an avoidance target after a period 54, but the avoidance control is actually started at the position where the avoidance control is started. Since it is far from the own vehicle 50, it is possible to secure control margin time for avoidance.
- avoidance control is actually started after the bicycle 53 enters the sensor detection area 51 and is identified as an avoidance target after a period 54; Since the location where the vehicle is located is close to the host vehicle 50, it is not possible to secure sufficient control time for avoidance. In reality, since the own vehicle 50 side also moves, it is more difficult to secure control margin time for avoidance control for obstacles coming from behind.
- Patent Document 1 the period 54 to be specified as an object to be avoided is not specified, so it cannot be handled in cases such as a bicycle 53 coming from behind. is difficult.
- avoidance control should simply be started at the stage of entering the sensor detection area 51 is difficult from the perspective of preventing malfunctions, and it is difficult to simply shorten the period 54 during which a detected object is specified as an object to be avoided. It's not realistic.
- the own vehicle when passing a moving object such as a bicycle while driving before an intersection, by storing recognition information of the moving object, the own vehicle can make a left turn at the intersection; (2) As a result of determining the possibility of collision, it is determined that there is a high possibility of a collision by reading recognition information stored in the past at the time of prediction and determining the possibility of a collision between the own vehicle and a moving object stored in the past. Using the information about the moving object, the detection timing and detection area in which the moving object is predicted to be detected within the sensor detection range of the own vehicle when the own vehicle makes a left turn are calculated as predictive recognition information.
- the vehicle control device 100 (FIG. 3) of this embodiment is mounted on the own vehicle 3, and performs collision avoidance control to avoid a collision between the own vehicle and an object in front of the own vehicle.
- This embodiment assumes that the collision avoidance control is performed on a general road 1 including a traffic light 2 and an intersection.
- FIG. 2 is a conceptual diagram when the own vehicle 3 performs collision avoidance control for a two-wheeled vehicle 6 traveling from behind when turning left at an intersection, and shows the operation flow of this embodiment in Step. 1. Step. 2. Step. The operation will be explained in three parts.
- Step. 1 a vehicle 3 and a motorcycle 6 are traveling on a general road 1.
- the speed, relative position to the own vehicle, detection time, etc. are acquired as recognition information of the two-wheeled vehicle 6, and the two-wheeled vehicle 6 passes the two-wheeled vehicle 6.
- it is out of the sensor detection area 4 it is stored in the storage unit 5 as reusable information.
- Step. 2 the travel route of the own vehicle 3 is acquired from map information such as a navigation system, and it is determined whether there is a possibility that the own vehicle 3 will pass through an intersection.
- map information such as a navigation system
- the recognition information of the two-wheeled vehicle 6 stored in the storage unit 5 is read out, and from the read past recognition information, a collision between the two-wheeled vehicle 6 and the own vehicle 3 at the intersection when turning left is detected.
- the time required for the two-wheeled vehicle 6 to reach the intersection is calculated, assuming that the two-wheeled vehicle 6 moves in a straight line at a constant velocity from the time of detection.
- the calculated arrival times of the own vehicle 3 and the two-wheeled vehicle 6 at the intersection are compared, and the possibility that the two-wheeled vehicle 6 will come from behind at the timing when the own vehicle 3 turns left at the intersection is determined as a collision possibility. If it is determined that there is a high possibility of a collision, the recognition information (past recognition information) stored in the storage unit 5 as predictive recognition information is identified as an obstacle that is likely to be re-detected when turning left at the intersection.
- the recognition information of the moving object is stored, and when the vehicle is predicted to turn left at the intersection, the previously stored recognition information is read out and the vehicle is It becomes possible to judge the possibility of a collision between the vehicle and a moving object stored in the past.
- the remaining two actions are: (2) As a result of determining the possibility of collision, the information on the moving object identified as having a high collision probability is used to control the vehicle's own vehicle when making a left turn. A detection timing and a detection area where the moving body is predicted to be detected in the sensor detection range are calculated as predictive recognition information, and an area where the moving body is predicted to be detected in the sensor detection area at least in front of the host vehicle. (3) When the own vehicle turns left at an intersection, if an object is detected at the predicted detection timing or in the detection area, it is determined that the previously memorized moving object has been redetected, and avoidance control is performed. Regarding the operation of securing the control margin necessary for avoidance control by shortening the period for identifying the avoidance target to be executed, Step. This will be explained using 3.
- Step. 3 is a situation in which a two-wheeled vehicle 6 approaches from behind at the timing when the host vehicle 3 actually turns left at an intersection. It is determined that the own vehicle 3 will turn left at the intersection based on the control information of the direction indicator and the like. Step 1 is triggered by the vehicle 3 turning left at the intersection. It is determined whether the predicted recognition information calculated in step 2 exists. If predictive recognition information exists, the obstacle detection timing (also referred to as predicted detection timing) and the detection area (also referred to as predicted detection area) at the time of turning left at an intersection are predicted from the predictive recognition information, and the image 7 generated by the image processing unit is A prediction area 8 corresponding to the predicted detection area is set.
- the obstacle detection timing also referred to as predicted detection timing
- the detection area also referred to as predicted detection area
- the information on the moving object identified as having a high possibility of collision is used to determine the detection timing and detection when the moving object is predicted to be detected within the sensor detection range of the own vehicle when the own vehicle makes a left turn.
- the area can be calculated as predictive recognition information, and an area where the moving body is predicted to be detected can be set in the sensor detection area at least in front of the host vehicle.
- the time needed to detect an object, recognize the object for a certain period of time, and identify it as an object to avoid, which is difficult to simply shorten is achieved by using predictive recognition information. By adding it, it can be shortened. By shortening this time, the timing for starting avoidance control can be brought forward, so it is possible to secure control margin time for avoiding obstacles.
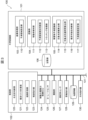
- FIG. 3 shows a configuration diagram of a vehicle control device in an embodiment of the present invention.
- the vehicle control device 100 of this embodiment includes an external world recognition unit 101 that performs obstacle recognition and traffic light recognition, a control unit 102 that actually instructs avoidance control, and a storage unit 106 that stores (saves) recognition information by the external world recognition unit 101.
- This is a vehicle control device that implements collision avoidance control.
- the external world recognition unit 101 acquires external world information in front of the own vehicle, and includes an image processing unit 103 for generating images used in recognition processing, detection of vehicles and lanes, and time-series tracking of detection targets. ), etc., and a recognition unit 104 that determines and predicts the possibility of a collision when the own vehicle turns left at an intersection based on past recognition information stored in a storage unit 106 that stores information recognized by the recognition unit 104. It has an obstacle prediction recognition unit 105 that generates recognition information.
- the obstacle prediction/recognition unit 105 uses an MPU or a positioning satellite that has high-precision map information such as data on road structures such as intersection width information, intersection stop line positions, and number of lanes, and information on three-dimensional objects on the road such as road signs and traffic light positions.
- the map information 129 is acquired from GNSS (GLOBAL NAVIGATION SATELLITE SYSTEM), etc., which acquires the position information of the own vehicle via the an intersection arrival time calculation unit 115 that calculates the intersection arrival time when the obstacle travels to the intersection in a uniform straight line motion and the intersection arrival time when the host vehicle reaches the intersection from the obstacle information (past recognition information) , a collision possibility determination unit 116 that calculates predictive recognition information by determining the possibility of collision from a comparison between the intersection arrival time of the vehicle and the obstacle calculated by the intersection arrival time calculation unit 115; Prediction reliability that adds reliability to the predictive recognition information calculated by , based on external factors that reduce detection accuracy such as the elapsed time since the obstacle was detected and the weather conditions when it was detected.
- GNSS GLOBAL NAVIGATION SATELLITE SYSTEM
- the reliability set by the prediction reliability setting unit 117 is based on an obstacle detected by the prediction area detection determination unit 112 (when the own vehicle turns left at an intersection), which will be described later, and is stored in the storage unit 106. It is used to determine the possibility of an obstacle detected in the past (determining the consistency or identity of obstacle detection information and past detection information).
- the recognition unit 104 includes a moving object detection unit 111 that identifies moving objects such as motorcycles traveling on general roads, a prediction area detection determination unit 112, and a tracking processing unit 113.
- the predicted area detection/judgment unit 112 receives the predictive recognition information from the obstacle predictive recognition unit 105 and selects an area (predicted area) in which the obstacle included in the predictive recognition information is predicted to be detected in the image captured by the imaging unit 126. is calculated, and the prediction area information is passed to the prediction area setting unit 110 of the image processing unit 103.
- the prediction area setting unit 110 sets a prediction area for the image captured by the imaging unit 126 (more specifically, for at least a part of the image) (see FIG. 2).
- the prediction area detection determination unit 112 determines whether or not it is detected in the predicted area.
- the predicted area detection determination unit 112 determines whether the detected obstacle has been detected in the past based on the conditions of whether or not a moving object is detected in the predicted area and the conditions of whether or not the time when the moving object was detected is the predicted time. The possibility that the object is an obstacle is determined, and the information is passed to the tracking processing unit 113.
- the predicted area detection/judgment unit 112 judges whether the detection information of the detected moving body is the same as the past detection information of the moving body based on the predicted detection timing and the predicted detection area, and performs the tracking process. Hand it over to Department 113.
- the tracking processing unit 113 normally performs vehicle and lane detection, time-series tracking of a detection target, etc., but in the case of collision avoidance control in this embodiment, in order to identify it as an avoidance target to be subjected to avoidance control. First, it is necessary to perform tracking processing for a certain period of time after detecting an obstacle for the first time, and to determine whether or not the obstacle is likely to collide with the obstacle.
- the tracking processing unit 113 of this embodiment is configured to perform processing when predictive recognition information indicating that the detected obstacle is likely to be an obstacle detected in the past is passed (in other words, when the detected obstacle is (If it is determined that the detection information of the moving object and the past detection information of the moving object included in the predictive recognition information are the same), the detection This makes it possible to shorten the tracking processing time for specifying obstacles as objects to be avoided. This makes it possible to shorten the period for identifying an object to be avoided for which collision avoidance control is to be performed.
- the control unit 102 controls the own vehicle based on the external world information acquired by the external world recognition unit 101, and includes a right/left turn determination unit 120, a collision risk calculation unit 121, a route planning unit 122, and a control instruction unit 123.
- the left/right turn determination unit 120 determines whether the own vehicle is in a right/left turn state based on information from the yaw rate sensor 125, steering angle sensor 127, and direction indicator 130.
- the collision risk calculation unit 121 calculates the time to collision (TTC) for the obstacle that has a high possibility of collision as determined by the external world recognition unit 101 (in other words, is identified as an object to be avoided in avoidance control). Determines the risk of collision and determines whether or not to execute avoidance control.
- the route planning unit 122 calculates a travel route for collision avoidance.
- the control instruction unit 123 calculates a control value for collision avoidance control and instructs the braking force/driving force control ECU 124.
- the braking force/driving force control ECU 124 issues appropriate control instructions to each actuator of the vehicle according to the control instruction value from the control instruction section 123.
- the warning instruction unit 128 uses the information from the collision risk calculation unit 121 to issue a warning to the driver that the danger of a collision is approaching, or to display to the driver that avoidance control is in progress during collision avoidance control. It plays the role of giving notice by sound blowing. Further, the above configurations are connected to each other by a communication network 131.
- the external world recognition unit 101 is an imaging unit (camera sensor) that is mounted in front of the vehicle and captures an image of at least the area in front of the own vehicle as a means for acquiring external world information at least in front of the own vehicle.
- imaging unit camera sensor
- radar sensor a combination of other sensors.
- the external world recognition unit 101 and the control unit 102 operate independently in this embodiment, a configuration in which the external world recognition unit 101 and the control unit 102 are integrated is also applicable.
- the obstacle prediction recognition unit 105 acquires detection information from the storage unit 106 when determining the possibility of collision, but in order to reduce the data calculation load, it acquires detection information from the width information of the detected obstacle included in the detection information.
- the data to be acquired may be limited by filtering whether the vehicle is a two-wheeled vehicle or not.
- the storage unit 106 may be shared with the normal storage unit used in the external world recognition unit 101, or may be independently arranged as a storage unit dedicated to this embodiment.
- the number of prediction regions set by the prediction region setting unit 110 is not limited to one, but may be set in multiple numbers. At this time, the method for setting the prediction area may be changed depending on the reliability included in the prediction recognition information.
- the prediction area set by the prediction area setting unit 110 is configured to delete the setting information from the storage unit 106 if the setting information is not detected even after the predicted detection time based on the detection timing included in the prediction recognition information. I can do it. In other words, if the moving object included in the predictive recognition information is not detected even after the detection timing predicted in the prediction area set by the prediction area setting unit 110, the predictive recognition information is deleted from the storage unit 106. I can do it.
- the collision possibility determining unit 116 determines the possibility of a collision
- a method of simply determining the collision possibility by comparing the arrival times of the own vehicle 3 and the two-wheeled vehicle 6 at the intersection is explained.
- methods for improving the accuracy of determining the possibility of collision such as predicting the future route of the two-wheeled vehicle 6 and determining the possibility of collision, are not limited to this embodiment.
- the time it takes for the own vehicle 3 to reach the intersection varies depending on the driver's control, from when the collision possibility determination unit 116 determines the possibility of collision until the vehicle 3 reaches the intersection. It may be performed at any time (cycle time) until the intersection is reached.
- the left/right turn determining unit 120 may determine whether to turn right or left by acquiring the steering angle control value.
- the intersection distance calculation unit 114 calculates the intersection distance from the information in the map information 129, but it may also be calculated from the recognition result of a sensor (such as a camera sensor) attached to the own vehicle. , may be calculated based on road-to-vehicle communication information received from a roadside communication device. In other words, as a trigger for calculating the intersection distance and reading out the obstacle information (past detection information) from the storage unit 106, the vehicle's travel route is calculated from the map information 129, and it is determined that there is a high possibility of turning left or right at the intersection.
- the past detection information may be read out by the external world recognition unit 101, or the past detection information may be read out by determining that there is a high possibility of turning left or right at the intersection based on the intersection recognition result by the external world recognition unit 101.
- the past detection information may be read by determining that there is a high possibility of turning left or right at the intersection using the intersection information obtained.
- Figure 4 When passing a moving object such as a bicycle while driving before an intersection, the own vehicle makes a left turn at the intersection by storing the recognition information of the moving object.
- Figure 5 shows the operation of reading previously stored recognition information when a collision is predicted and determining the possibility of a collision between the own vehicle and a previously stored moving object.
- a collision is Using information on moving objects that have been identified as having a high possibility of being detected, predicts and recognizes the detection timing and detection area in which the moving object is predicted to be detected within the sensor detection range of the own vehicle when making a left turn.
- Step. From Step 1. 3 is Step.3 in FIG. From Step 1. It corresponds to 3.
- the external world recognition unit 101 attached to the own vehicle acquires external world information in front of the own vehicle (S300). It is determined whether a two-wheeled vehicle is included in the acquired external world information (S301), and if No, the process returns to S300, and if Yes, the process proceeds to S302.
- the detection information and detection time of the two-wheeled vehicle recognized by the recognition unit 104 are stored in the storage unit 106 (S302).
- the obstacle prediction recognition unit 105 acquires travel plan information of the own vehicle from the map information 129, position information of the own vehicle, etc. (S303). The obstacle prediction recognition unit 105 determines the possibility of collision when the own vehicle turns right or left based on the moving object information among the obstacle information (past recognition information) stored in the storage unit 106, and determines whether the collision possibility is high. Obstacles determined as such are extracted (S304).
- the right/left turn determination unit 120 determines whether the own vehicle will turn left or right (S305), and if No, the process returns to S300, and if Yes, the process proceeds to S306. Identify moving objects that are likely to collide with your vehicle when turning left or right, and determine the predicted detection timing (predicted detection timing) and detection area (predicted detection area) when the vehicle is detected in the detection area of your vehicle when turning left or right. ) is acquired as predictive recognition information (S306). It is determined whether an obstacle is detected in the detection area of the own vehicle (S307). If No, the process returns to S306, and if Yes, the process proceeds to S308.
- the actual detection timing and detection area detected in S307 are compared with the predicted recognition information, and it is determined that the obstacle actually detected in S307 is the same as the obstacle specified by the predicted recognition information.
- the possibility that this is the case is determined (S308). In other words, when the own vehicle makes a right or left turn, it is determined whether the detection information of the moving object actually detected in S307 is the same as the past detection information of the moving object included in the predictive recognition information. If it is determined that the possibility is high, the process advances to S309, and if it is determined that the possibility is low, the process advances to S310.
- the recognition information stored in the past can be used when the vehicle is predicted to turn left at the intersection.
- the operation of reading out previously stored recognition information and determining the possibility of a collision between the own vehicle and a previously stored moving object among the operations of reading out and determining the possibility of a collision between the own vehicle and a previously stored moving object. This will be explained using FIG. 5.
- the obstacle prediction recognition unit 105 acquires travel plan information of the own vehicle from the map information 129, position information of the own vehicle, etc. (S400). The obstacle prediction recognition unit 105 determines whether the own vehicle is scheduled to pass through an intersection based on the map information 129, the position information of the own vehicle, etc. (S401). If No, the process returns to S400, and if Yes, the process proceeds to S402. Mobile object information is read out of the past recognition information stored in the storage unit 106 (S402). The prediction reliability setting unit 117 calculates and adds reliability to the moving object information read from the storage unit 106 based on the time when the moving object was detected, the detection accuracy, etc. (S403).
- the intersection distance calculation unit 114 calculates the distance to the intersection from the current location of the host vehicle and the information in the map information 129 (S404).
- the intersection arrival time calculation unit 115 calculates the predicted intersection arrival time when the own vehicle reaches the intersection and turns left or right from the intersection distance information calculated in S404 (S405).
- the collision possibility determination unit 116 calculates the intersection turning time (intersection arrival time) for each of the moving object information read in S402, and calculates the collision possibility for each moving object information when the host vehicle turns left or right. A determination is made for each piece of body information (S406).
- the prediction reliability setting unit 117 evaluates and sets reliability for the determined collision possibility (S407).
- moving object information with a high possibility of colliding with the host vehicle when turning left or right at an intersection is identified, and is passed to the recognition unit 104 as predictive recognition information (S408 ).
- the moving object is detected within the sensor detection range of the own vehicle when the own vehicle makes a left turn, using information on the moving object identified as having a high possibility of collision.
- the operation of calculating the predicted detection timing and detection area as predicted recognition information and setting the area where the moving body is predicted to be detected in at least the sensor detection area in front of the host vehicle is described using FIG. explain.
- the right/left turn determination unit 120 detects that the own vehicle is making a right/left turn (S500). If No, the process returns to S500, and if Yes, the process proceeds to S501.
- the recognition unit 104 determines whether the predictive recognition information described in FIG. 5 (determined by the collision possibility determination unit 116) has been received from the obstacle predictive recognition unit 105 (S501). If No, the process ends, and if Yes, the process advances to S502.
- the recognition unit 104 calculates and predicts the timing at which the own vehicle will collide with a moving object that is included in the received predictive recognition information and is likely to collide with a moving object when the own vehicle turns right or left (S502).
- the recognition unit 104 calculates a sensor detection area where detection is predicted to occur when the vehicle makes a right or left turn from the relative position information of the moving body with respect to the vehicle included in the predicted recognition information (S503).
- the prediction area setting unit 110 of the image processing unit 103 sets a prediction area (see FIG. 2) in (at least a part of) the sensor detection area at least in front of the own vehicle based on the calculated collision timing and prediction recognition information including sensor detection area information. ) is set as the sensor detection area (S504).
- the right/left turn determination unit 120 determines whether the own vehicle is under right/left turn control (S600). If No, the process ends, and if Yes, the process advances to S601.
- the recognition unit 104 determines whether a moving object is detected at least in the sensor detection area in front of the host vehicle (S601). If No, the process returns to S600, and if Yes, the process proceeds to S602.
- the predicted area detection determination unit 112 of the recognition unit 104 compares the collision timing included in the predicted recognition information calculated in the operation of FIG. 6 for the moving object detected in S601 with the timing at which the moving object was actually detected ( S602). In other words, it is determined whether the moving object is detected at the predicted collision timing.
- the prediction area detection determination unit 112 determines whether the moving object detected in S601 is detected within the prediction area set in the operation of FIG. 6 (S603). In other words, it is determined whether a moving object is detected in the prediction area. If No, the process advances to S604; if Yes, the process advances to S606. That is, with respect to the detection information of the moving object detected in S601 when the own vehicle turns right or left, it is determined whether or not it is the same as the past detection information of the moving object included in the predictive recognition information, based on the predicted detection timing and the predicted detection area. to decide.
- the prediction area detection determination unit 112 determines that there is a low possibility that the moving object detected in S601 is the same as a moving object that was recognized in the past and determined to have a high possibility of colliding, which is included in the predictive recognition information. The judgment is made and the setting of the prediction area set in FIG. 6 is canceled (S604). Then, tracking processing performed in normal collision avoidance control is performed (S605).
- the prediction area is detected if the moving object detected in S601 is likely to be the same as a moving object that was recognized in the past and determined to have a high possibility of collision, which is included in the predictive recognition information.
- the determining unit 112 makes a determination. That is, it is determined that the detection information of the moving object detected in S601 when the host vehicle turns left or right is the same as the past detection information of the moving object included in the predictive recognition information. In that case, tracking processing is performed only on moving objects detected in the prediction area, and predictive recognition information is used to reduce the number of detections (tracking processing time) required for tracking processing to identify the avoidable object. This makes it possible to simplify the tracking processing method while maintaining detection accuracy.
- the control unit 102 performs collision avoidance control or a warning for the avoidance target identified by the recognition processing in S605 and S606 (S607).
- the left/right turn determination unit 120 acquires control information for the direction indicator 130 (S700).
- the right/left turn determination unit 120 acquires information on the own vehicle position from the information from the yaw rate sensor 125, the map information 129, etc. (S701). Based on the information acquired in S700, it is determined whether the turn signal is operated to turn left or right (S702). Based on the yaw rate sensor information acquired in S701, it is determined whether the own vehicle is changing in the same direction as the direction indicated by the turn signal (S703). If the determination results in S702 and S703 are Yes, the right/left turn determination unit 120 determines that the vehicle is in a left or right turn state (S704).
- the recognition information of the moving object is stored, so that when the own vehicle is predicted to turn left at the intersection, the past memorized information is stored.
- the vehicle control device 100 of the present embodiment includes an external world recognition unit 101 that acquires external world information at least in front of the own vehicle, and a and a storage unit 106 that stores detection information of the moving body acquired (detected) by the external world recognition unit 101 when the host vehicle overtakes the moving body.
- the external world recognition unit 101 reads past detection information of the mobile body stored in the storage unit 106 and determines the possibility of a collision between the host vehicle and the mobile body. Based on the collision possibility, a moving object (predicted detection timing and predicted detection area) that is likely to collide with the own vehicle when changing the course of the own vehicle is set as predictive recognition information (obstacle predictive recognition).
- section 105 determining whether detection information of a moving object detected by the external world recognition section when the host vehicle changes course is the same as past detection information of the moving object included in the predictive recognition information (recognition section 105). Section 104).
- the vehicle control device 100 determines that the detection information of the moving object detected by the external world recognition unit 101 when the host vehicle changes course and the past detection information of the moving object included in the predictive recognition information are the same. If it is determined, the period during which collision avoidance control is specified as an object to be avoided is shortened, the moving object is specified as an object to be avoided, and the process moves to avoidance control or warning for the moving object (recognition unit 104).
- the predicted recognition information includes a predicted detection timing and a predicted detection area of the moving body
- the vehicle control device 100 includes at least part of the external world information of the host vehicle acquired by the external world recognition unit 101, A predicted detection area in which a body is predicted to be detected by the external world recognition unit 101 when the vehicle changes course (the detection area is predicted) is set; A predicted detection timing that is predicted to be detected by the unit 101 (predicted detection timing) is set, and the detection information of the moving object detected by the external world recognition unit 101 when the own vehicle changes course is set. It is determined whether the predicted detection timing and the predicted detection area are the same as the past detection information of the moving object (recognition unit 104).
- the vehicle control device 100 compares the intersection arrival time of the own vehicle and the intersection arrival time of the mobile body calculated from past detection information of the mobile body, and determines the collision possibility (an obstacle prediction recognition unit 105).
- the vehicle control device 100 determines that the detection information of the moving object detected by the external world recognition unit 101 when the host vehicle changes course and the past detection information of the moving object included in the predictive recognition information are the same. If it is determined, the tracking processing time for specifying the moving object as an avoidable object for collision avoidance control is shortened and the moving body is specified as an avoidable object (recognition unit 104).
- the vehicle control device 100 sets the predicted detection area in a part of the image captured by a camera sensor that captures at least an image in front of the host vehicle (recognition unit 104).
- the vehicle control device 100 sets reliability for the predictive recognition information based on the time when the moving object was detected and detection accuracy (weather conditions, etc.), and sets the reliability based on the detection information and the past detection information. Used to determine consistency (identity).
- the vehicle control device 100 includes a control unit 102 that performs collision avoidance control to avoid a collision between the own vehicle and an object in front of the own vehicle, and an external world recognition unit 101 that performs obstacle recognition. , a storage unit 106 that stores obstacle recognition information, and calculates the distance to the intersection and the intersection arrival time of the own vehicle, and calculates the possibility that the own vehicle will collide with each of the obstacle information stored in the storage unit 106 when turning left at the intersection. Obstacle prediction recognition unit 105 determines whether or not the object is likely to be detected and generates predictive recognition information, and determines from the predictive recognition information the obstacles that the vehicle is likely to collide with when turning left at an intersection.
- the vehicle control device 100 includes a prediction area setting unit that sets an area where the vehicle will turn left at an intersection, and when an obstacle is detected in the prediction area set by the prediction area setting unit when the own vehicle turns left at an intersection, the vehicle control device 100 By shortening the time it takes to determine that a moving object has been re-detected and identify it as an avoidance target for which avoidance control is to be performed, the control margin time necessary for avoidance control is secured.
- the vehicle control device 100 stores recognition information when passing a motorcycle, reads recognition information of motorcycles that have been recognized in the past when turning right or left at an intersection, and determines and predicts the possibility of collision with the own vehicle. By calculating the recognition information, when the vehicle actually detects an obstacle when making a left turn, it uses the predictive recognition information to immediately confirm that it is a re-detection of a previously recognized moving object, and provides means and devices for performing avoidance control. provide.
- the own vehicle when the own vehicle runs on the road before the intersection, (1) when passing a moving object such as a bicycle while driving before the intersection, the own vehicle makes a left turn at the intersection by storing recognition information of the moving object; (2) As a result of determining the possibility of a collision, the recognition information stored in the past is read out when a collision is predicted to occur, and the possibility of a collision between the own vehicle and the moving object stored in the past is determined.
- the detection timing and detection area in which the moving object is predicted to be detected within the sensor detection range of the own vehicle when the own vehicle makes a left turn are calculated as predictive recognition information.
- each of the above-mentioned configurations, functions, processing units, processing means, etc. may be partially or entirely realized in hardware by designing, for example, an integrated circuit.
- each of the above configurations, functions, etc. may be realized by software by a processor interpreting and executing a program for realizing each function.
- Information such as programs, tables, files, etc. that realize each function can be stored in a storage device such as a memory, a hard disk, or an SSD (Solid State Drive), or a recording medium such as an IC card, an SD card, or a DVD.
- Intersection arrival time calculation unit 116 Collision possible Prediction reliability setting unit 120
- Collision risk calculation unit 122 Route planning unit 123
- Control instruction unit 124 Braking force/drive force control ecu 125
- Yaw rate sensor 126 ...Imaging unit 127
- Steering angle sensor 128 ...Alarm instruction unit 129
- Map information 130 ...Direction indicator 131...Communication network
Landscapes
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Traffic Control Systems (AREA)
Abstract
Description
2・・・信号機
3・・・自車両
4・・・センサ検知領域
5・・・記憶部
6・・・二輪車
7・・・画像処理部が生成する画像
8・・・予測領域
50・・・自車両
51・・・センサ検知領域
52・・・自転車
53・・・自転車
54・・・回避対象として特定する期間
55・・・交差点を有する一般道路
100・・・車両制御装置
101・・・外界認識部
102・・・制御部
103・・・画像処理部
104・・・認識部
105・・・障害物予測認識部
106・・・記憶部
110・・・予測領域設定部
111・・・移動体検知部
112・・・予測領域検知判断部
113・・・トラッキング処理部
114・・・交差点距離算出部
115・・・交差点到達時間算出部
116・・・衝突可能性判断部
117・・・予測信頼度設定部
120・・・右左折判断部
121・・・衝突リスク計算部
122・・・経路計画部
123・・・制御指示部
124・・・制動力/駆動力制御ECU
125・・・ヨーレートセンサ
126・・・撮像部
127・・・操舵角センサ
128・・・警報指示部
129・・・地図情報
130・・・方向指示器
131・・・通信網
Claims (13)
- 自車両の少なくとも前方の外界情報を取得する外界認識部と、
前記外界認識部により取得された前記外界情報に基づき前記自車両を制御する制御部と、
前記自車両が移動体を追い越す際に、前記外界認識部により取得した前記移動体の検知情報を記憶する記憶部と、を備え、
前記外界認識部は、前記自車両の進路変更が予測された際、前記記憶部に記憶された前記移動体の過去検知情報を読み出し、前記自車両と前記移動体との衝突可能性を判断し、前記衝突可能性に基づき、前記自車両の進路変更時に前記自車両と衝突する可能性が高い移動体を予測認識情報として設定し、前記自車両が進路変更する時に前記外界認識部により検知された移動体の検知情報が前記予測認識情報に含まれる前記移動体の過去検知情報と同一か否かを判断することを特徴とする車両制御装置。 - 前記車両制御装置は、前記自車両が進路変更する時に前記外界認識部により検知された移動体の検知情報と前記予測認識情報に含まれる前記移動体の過去検知情報とが同一であると判断された場合、衝突回避制御の回避対象として特定する期間を短縮して前記移動体を回避対象として特定し、前記移動体に対する回避制御または警報に移行することを特徴とする、請求項1に記載の車両制御装置。
- 前記予測認識情報は、前記移動体の予測検知タイミングと予測検知領域を含み、
前記車両制御装置は、前記外界認識部により取得する前記自車両の前記外界情報の少なくとも一部に、前記移動体が前記自車両の進路変更時に前記外界認識部により検知されると予測される予測検知領域を設定し、前記移動体が前記自車両の進路変更時に前記外界認識部により検知されると予測される予測検知タイミングを設定し、前記自車両が進路変更する時に前記外界認識部により検知された移動体の検知情報に対し、前記予測検知タイミングと前記予測検知領域を条件として前記移動体の過去検知情報と同一か否かを判断することを特徴とする、請求項1に記載の車両制御装置。 - 前記車両制御装置は、前記自車両の交差点到達時間と前記移動体の過去検知情報から算出する前記移動体の交差点到達時間とを比較し、前記衝突可能性を判断することを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記自車両が進路変更する時に前記外界認識部により検知された移動体の検知情報と前記予測認識情報に含まれる前記移動体の過去検知情報とが同一であると判断された場合、衝突回避制御の回避対象として特定するためのトラッキング処理時間を短縮して前記移動体を回避対象として特定することを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記自車両の少なくとも前方を撮像するカメラセンサで撮像された画像の一部に前記予測検知領域を設定することを特徴とする、請求項3に記載の車両制御装置。
- 前記車両制御装置は、前記衝突可能性判断を前記自車両が交差点に到達するまで随時実施することを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記予測検知領域に前記予測検知タイミングを過ぎても前記予測認識情報に含まれる前記移動体が検知されなかった場合、前記記憶部から前記予測認識情報を削除することを特徴とする、請求項3に記載の車両制御装置。
- 前記車両制御装置は、前記予測認識情報に対し、前記移動体が検知された時間と検知精度から信頼度を設定し、前記信頼度を前記検知情報と前記過去検知情報の一致性判断に利用することを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記過去検知情報の読み出しトリガとして、地図情報から前記自車両の走行経路を算出し、交差点右左折可能性が高いと判断することで前記過去検知情報を読み出すことを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記過去検知情報の読み出しトリガとして、前記外界認識部による交差点認識結果から、交差点右左折可能性が高いと判断することで前記過去検知情報を読み出すことを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記過去検知情報の読み出しトリガとして、路車間通信により取得した交差点情報を利用し、交差点右左折可能性が高いと判断することで前記過去検知情報を読み出すことを特徴とする、請求項1に記載の車両制御装置。
- 前記車両制御装置は、前記自車両が進路変更する時に前記外界認識部により検知された移動体の検知情報と前記予測認識情報に含まれる前記移動体の過去検知情報とが同一でないと判断された場合、前記予測検知領域の設定を解除することを特徴とする、請求項3に記載の車両制御装置。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202380052588.2A CN119522449A (zh) | 2022-07-21 | 2023-03-08 | 车辆控制装置 |
| JP2024534921A JP7804770B2 (ja) | 2022-07-21 | 2023-03-08 | 車両制御装置 |
| DE112023002379.4T DE112023002379T5 (de) | 2022-07-21 | 2023-03-08 | Fahrzeugsteuervorrichtung |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2022116603 | 2022-07-21 | ||
| JP2022-116603 | 2022-07-21 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024018682A1 true WO2024018682A1 (ja) | 2024-01-25 |
Family
ID=89617540
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2023/008872 Ceased WO2024018682A1 (ja) | 2022-07-21 | 2023-03-08 | 車両制御装置 |
Country Status (4)
| Country | Link |
|---|---|
| JP (1) | JP7804770B2 (ja) |
| CN (1) | CN119522449A (ja) |
| DE (1) | DE112023002379T5 (ja) |
| WO (1) | WO2024018682A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20250236294A1 (en) * | 2024-01-23 | 2025-07-24 | Toyota Jidosha Kabushiki Kaisha | Traveling control device, traveling control method, and non-transitory recording medium |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2009122918A (ja) * | 2007-11-14 | 2009-06-04 | Tokai Rika Co Ltd | 車両走行支援装置 |
| JP2010102529A (ja) * | 2008-10-24 | 2010-05-06 | Mitsubishi Electric Corp | 情報提供装置および情報提供方法 |
| JP6617696B2 (ja) * | 2016-12-14 | 2019-12-11 | 株式会社デンソー | 車両制御装置、車両制御方法 |
-
2023
- 2023-03-08 WO PCT/JP2023/008872 patent/WO2024018682A1/ja not_active Ceased
- 2023-03-08 CN CN202380052588.2A patent/CN119522449A/zh active Pending
- 2023-03-08 JP JP2024534921A patent/JP7804770B2/ja active Active
- 2023-03-08 DE DE112023002379.4T patent/DE112023002379T5/de active Pending
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2009122918A (ja) * | 2007-11-14 | 2009-06-04 | Tokai Rika Co Ltd | 車両走行支援装置 |
| JP2010102529A (ja) * | 2008-10-24 | 2010-05-06 | Mitsubishi Electric Corp | 情報提供装置および情報提供方法 |
| JP6617696B2 (ja) * | 2016-12-14 | 2019-12-11 | 株式会社デンソー | 車両制御装置、車両制御方法 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20250236294A1 (en) * | 2024-01-23 | 2025-07-24 | Toyota Jidosha Kabushiki Kaisha | Traveling control device, traveling control method, and non-transitory recording medium |
Also Published As
| Publication number | Publication date |
|---|---|
| CN119522449A (zh) | 2025-02-25 |
| DE112023002379T5 (de) | 2025-04-03 |
| JP7804770B2 (ja) | 2026-01-22 |
| JPWO2024018682A1 (ja) | 2024-01-25 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US12012095B2 (en) | Vehicle and method of controlling the same | |
| KR102683742B1 (ko) | 차량 및 그 제어방법 | |
| US10919525B2 (en) | Advanced driver assistance system, vehicle having the same, and method of controlling the vehicle | |
| CN110281930B (zh) | 车辆控制装置、车辆、车辆控制方法以及存储介质 | |
| JP4933962B2 (ja) | 分岐路進入判定装置 | |
| EP3366540B1 (en) | Information processing apparatus and non-transitory computer-readable recording medium | |
| CN114056325B (zh) | 降低碰撞风险的装置及方法 | |
| JP7227072B2 (ja) | 車両制御装置 | |
| JP7401978B2 (ja) | 交差点発進判定装置 | |
| KR102797063B1 (ko) | 차량 및 그 제어방법 | |
| JP2005511374A (ja) | 自動車を自動的に監視するシステム | |
| US11370489B2 (en) | Vehicle and method for steering avoidance control | |
| KR102930139B1 (ko) | 차량 및 그 제어방법 | |
| JP2012519346A (ja) | 自動車の運転操縦の自動認識方法及びこの方法を含む運転者援助システム | |
| JP2019159756A (ja) | 車両制御装置およびコンピュータプログラム | |
| JP7554276B2 (ja) | 運転支援装置 | |
| JP7167977B2 (ja) | 車両走行支援方法及び車両走行支援装置 | |
| JP7302582B2 (ja) | 車両制御システム | |
| CN111791885B (zh) | 用于预测碰撞的车辆和方法 | |
| JP2005138623A (ja) | 車両走行支援装置 | |
| JP2023019038A (ja) | 運転支援装置 | |
| JP7614408B2 (ja) | 車載電子制御装置 | |
| JP7804770B2 (ja) | 車両制御装置 | |
| JP2025148615A (ja) | 外界認識装置、および、外界認識方法 | |
| KR102426854B1 (ko) | 자율주행차량의 차간거리 인식장치 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 23842619 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2024534921 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202380052588.2 Country of ref document: CN |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 18996663 Country of ref document: US |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 112023002379 Country of ref document: DE |
|
| WWP | Wipo information: published in national office |
Ref document number: 202380052588.2 Country of ref document: CN |
|
| WWP | Wipo information: published in national office |
Ref document number: 112023002379 Country of ref document: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 23842619 Country of ref document: EP Kind code of ref document: A1 |