WO2019003907A1 - サスペンション制御装置 - Google Patents
サスペンション制御装置 Download PDFInfo
- Publication number
- WO2019003907A1 WO2019003907A1 PCT/JP2018/022508 JP2018022508W WO2019003907A1 WO 2019003907 A1 WO2019003907 A1 WO 2019003907A1 JP 2018022508 W JP2018022508 W JP 2018022508W WO 2019003907 A1 WO2019003907 A1 WO 2019003907A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- high voltage
- control device
- controller
- control
- electrode
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G17/00—Resilient suspensions having means for adjusting the spring or vibration-damper characteristics, for regulating the distance between a supporting surface and a sprung part of vehicle or for locking suspension during use to meet varying vehicular or surface conditions, e.g. due to speed or load
- B60G17/015—Resilient suspensions having means for adjusting the spring or vibration-damper characteristics, for regulating the distance between a supporting surface and a sprung part of vehicle or for locking suspension during use to meet varying vehicular or surface conditions, e.g. due to speed or load the regulating means comprising electric or electronic elements
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G17/00—Resilient suspensions having means for adjusting the spring or vibration-damper characteristics, for regulating the distance between a supporting surface and a sprung part of vehicle or for locking suspension during use to meet varying vehicular or surface conditions, e.g. due to speed or load
- B60G17/06—Characteristics of dampers, e.g. mechanical dampers
- B60G17/08—Characteristics of fluid dampers
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16F—SPRINGS; SHOCK-ABSORBERS; MEANS FOR DAMPING VIBRATION
- F16F15/00—Suppression of vibrations in systems; Means or arrangements for avoiding or reducing out-of-balance forces, e.g. due to motion
- F16F15/02—Suppression of vibrations of non-rotating, e.g. reciprocating systems; Suppression of vibrations of rotating systems by use of members not moving with the rotating systems
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16F—SPRINGS; SHOCK-ABSORBERS; MEANS FOR DAMPING VIBRATION
- F16F9/00—Springs, vibration-dampers, shock-absorbers, or similarly-constructed movement-dampers using a fluid or the equivalent as damping medium
- F16F9/32—Details
- F16F9/44—Means on or in the damper for manual or non-automatic adjustment; such means combined with temperature correction
- F16F9/46—Means on or in the damper for manual or non-automatic adjustment; such means combined with temperature correction allowing control from a distance, i.e. location of means for control input being remote from site of valves, e.g. on damper external wall
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16F—SPRINGS; SHOCK-ABSORBERS; MEANS FOR DAMPING VIBRATION
- F16F9/00—Springs, vibration-dampers, shock-absorbers, or similarly-constructed movement-dampers using a fluid or the equivalent as damping medium
- F16F9/32—Details
- F16F9/53—Means for adjusting damping characteristics by varying fluid viscosity, e.g. electromagnetically
Definitions
- the present invention relates to a suspension control apparatus mounted on a vehicle such as a four-wheeled vehicle.
- a damping force adjustable shock absorber for example, as a suspension is provided between the vehicle body (spring) side and each wheel (spring under) side.
- the damping force adjustment is configured such that the generated damping force is variably controlled by applying an electric field by a high voltage in a state where an electrorheological fluid (ERF: Electro Rheological Fluid) is enclosed in a cylinder.
- EMF Electro Rheological Fluid
- a shock absorber (ER damper) is known (see, for example, Patent Document 1).
- An object of the present invention is to provide a suspension control device capable of improving the response of damping force control.
- a suspension control device comprises a vehicle behavior detection unit for detecting the behavior of the vehicle, a damping force adjustable shock absorber provided between two members of the vehicle moving relative to each other, and a detection result of the vehicle behavior detection unit. And a controller for adjusting the damping force of the damping force adjustable shock absorber.
- the damping force adjustable shock absorber includes a cylinder in which an electrorheological fluid is sealed, a piston slidably inserted in the cylinder, and a piston rod connected to the piston and extending outside the cylinder. And an electrode which is provided at a portion where the flow of the electrorheological fluid is generated by the movement of the piston in the cylinder, and which applies an electric field to the electrorheological fluid.
- the control device determines a high voltage command value for variably adjusting the damping force based on the detection result of the vehicle behavior detection unit, and the high voltage command output from the command control device And a high voltage control device for feedback controlling a high voltage applied to the electrode based on a value.
- the high voltage control device comprises: an HV charge controller for outputting a transformer control signal for performing charge control of high voltage applied to the electrode; and HV charge control for transforming the high voltage applied to the electrode.
- an HV cascode for performing the discharge control according to the cascode control signal from the HV discharge controller.
- the suspension control apparatus can improve responsiveness when performing damping force control.
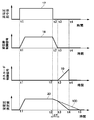
- FIG. 5 is a characteristic diagram showing characteristics of a high voltage command value, a transformer control signal, a cascode control signal and a high voltage measurement value.
- FIGS. 1 to 4 of the accompanying drawings taking a case where it is mounted on a four-wheeled vehicle.
- a vehicle body 1 constitutes a body of a vehicle.
- wheels 2 for example, left and right front wheels and left and right rear wheels are collectively referred to as a wheel 2 that together with the vehicle body 1 are provided.
- the wheel 2 is configured to include a tire 3, and the tire 3 acts as a spring that absorbs fine irregularities of the road surface.
- the suspension device 4 is provided between two relatively moving members of the vehicle (for example, between the vehicle body 1 and the wheel 2).
- the suspension device 4 includes a suspension spring 5 (hereinafter referred to as a spring 5) and a damping force adjustable type shock absorber described later disposed in parallel with the spring 5 and between the two members (between the vehicle body 1 and the wheel 2).
- Device 21 (hereinafter referred to as ER damper 21).
- FIG. 1 the case where one set of suspension devices 4 is provided between the vehicle body 1 and the wheels 2 is illustrated. However, a total of four sets of suspension devices 4 are provided independently and independently between, for example, four wheels 2 and the vehicle body 1, and only one of them is schematically shown in FIG.
- a sprung acceleration sensor 6 is provided on the vehicle body 1 side.
- the sprung acceleration sensor 6 is attached to the vehicle body 1 at a position near the ER damper 21 described later, for example.
- the sprung acceleration sensor 6 detects the upward and downward vibrational acceleration on the side of the vehicle body 1 which is a so-called sprung mass, and outputs a detection signal (that is, a signal of the sprung acceleration) to the command control device 9.
- an unsprung acceleration sensor 7 is provided on the wheel 2 side of the vehicle.
- the unsprung acceleration sensor 7 detects the upward and downward vibrational acceleration on the so-called unsprung wheel 2 side, and outputs a detection signal (that is, a signal of the unsprung acceleration) to the command control device 9.
- the sprung acceleration sensor 6 and the unsprung acceleration sensor 7 detect the behavior of the vehicle (more specifically, the up-and-down motion detection detecting state quantities related to the up and down motion of the vehicle) Part).
- the vehicle behavior detection unit need not necessarily be configured to include the sprung acceleration sensor 6 and the unsprung acceleration sensor 7 provided in the vicinity of the ER damper 21.
- the vehicle behavior detection unit can be configured by only the sprung acceleration sensor 6.
- the vehicle behavior detection unit may be configured by a vehicle height sensor (not shown) that detects a height position (vehicle height) in the upper and lower direction of the vehicle body 1 with respect to the wheel 2.
- the vehicle behavior detection unit is configured by a wheel speed sensor (not shown) that detects the rotational speed of the wheel 2, the acceleration sensors 6 and 7, and a sensor that detects the behavior (state quantity) of the vehicle other than the vehicle height sensor. It may be configured.
- the vertical motion of each wheel 2 is estimated as the vehicle behavior by, for example, estimating the vertical motion of each wheel 2 from the information (acceleration) of one sprung acceleration sensor 6 and the information (wheel speed) of the wheel speed sensor It may be configured to
- the controller 8 variably adjusts the generated damping force of the damping force adjustable shock absorber 21 (that is, the ER damper 21) based on the detection result of the vehicle behavior detection unit (for example, the acceleration sensors 6 and 7).
- Control device As shown in FIG. 1, the control device 8 includes a command control device 9 and a high voltage control device 11 described later.
- the command control device 9 of the control device 8 is disposed, for example, in a compartment of the vehicle body 1 or the like, and the high voltage control device 11 is attached to an outer cylinder 24 of an ER damper 21 described later as shown in FIG.
- the high voltage control device 11 is also an HV box that is detachably mounted on the radially outer side of the outer cylinder 24.
- the command control device 9 is called an ECU (Electronic Control Unit) for a suspension device, and includes, for example, a microcomputer. An input side of the command control device 9 is connected to the vehicle behavior detection unit (for example, the acceleration sensors 6 and 7), and an output side is connected to the high voltage control device 11. For these connections, for example, a communication line made up of CAN (Controller Area Network), which is a line network for performing data communication, can be used.
- CAN Controller Area Network
- the command control device 9 obtains a high voltage command value for variably adjusting the damping force based on the detection result of the vehicle behavior detection unit (for example, the acceleration sensors 6 and 7). That is, the command control device 9 variably adjusts the damping force of the ER damper 21 using, for example, the skyhook control law or the like based on the vehicle behavior information input from the sprung acceleration sensor 6 and the unsprung acceleration sensor 7.
- the high voltage command value is calculated, and the high voltage command value is output to the high voltage control device 11. That is, the control device 8 including the command control device 9 and the high voltage control device 11 variably adjusts the damping force generated by the ER damper 21 which is a damping force variable damper based on the detection result of the vehicle behavior detection unit. Control to do so.
- the battery 10 is a power source for applying a high voltage to the ER damper 21 (for example, an electrode cylinder 36 described later).
- the battery 10 is configured of, for example, a 12 V on-board battery (and an alternator that charges the on-board battery as needed), which is a battery for an accessory of a vehicle.
- the positive electrode side of the battery 10 is connected to the electrode cylinder 36 of the ER damper 21 via the high voltage control device 11, and the negative electrode side is connected to an outer cylinder 24 serving as a damper shell of the ER damper 21.
- the battery 10 is not only the high voltage control apparatus 11, but is also a power supply of the command control apparatus 9 grade
- a power source of the ER damper 21 for example, in the case of a hybrid car or an electric car equipped with an electric motor (drive motor) for traveling, a large capacity battery (not shown) for driving the vehicle can be used.
- the high voltage control device 11 is a device that variably controls a high voltage applied to the ER damper 21 (for example, the electrode cylinder 36).
- the high voltage control device 11 is connected to a battery 10 serving as a power supply via a battery line (batt line) 10A constituting a DC power line and a ground line (GND line) 10B.
- the high voltage control device 11 feeds back the high voltage to be applied to the electrode cylinder 36 of the ER damper 21 based on the high voltage command value output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12. It is to control.
- the high voltage control device 11 is connected on the input side thereof to the command control device 9 and the high voltage monitor 12 and the like, and on the output side thereof to the electrode cylinder 36 of the ER damper 21.
- the high voltage monitor 12 monitors (monitors or detects) the high voltage boosted by the high voltage controller 11 and outputs it as a high voltage measurement value to the high voltage controller 11 for feedback control.
- the high voltage monitor 12 may be configured by, for example, a high voltage detector provided on the output side of the high voltage control device 11 or the like.
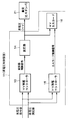
- the high voltage controller 11 is configured to include an HV charge controller 13, a transformer 14, an HV discharge controller 15 described later, and an HV cascode 16.
- the HV charge controller 13 applies a high voltage to the electrode cylinder 36 of the ER damper 21 based on the high voltage command value output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12.
- a transformer control signal for performing charge control is calculated and obtained, and this transformer control signal is output to the transformer 14.
- the transformer 14 performs transformation control of a high voltage applied to the electrode cylinder 36 in accordance with the transformer control signal output from the HV charge controller 13.
- the high voltage command value output from the command control device 9 is output as a high level during time t1 to t2, as shown by the characteristic line 17 shown in FIG. 4, for example.
- the HV charge controller 13 outputs a transformer control signal over the time t1 to t3 as shown by the characteristic line 18.
- the transformer 14 performs transformation control so as to boost, for example, the DC voltage from the battery 10 in accordance with the transformer control signal output from the HV charge controller 13, and the boosted high voltage (HV) is an electrode of the ER damper 21. Supply (output) to the cylinder 36.
- the HV discharge controller 15 of the high voltage control device 11 performs discharge control so as to step down the voltage applied to the electrode cylinder 36 of the ER damper 21. That is, the HV discharge controller 15 performs discharge control of the high voltage applied to the electrode cylinder 36 based on the high voltage command value output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12.
- the cascode control signal is calculated and determined, and the cascode control signal is output to the HV cascode 16.
- the HV cascode 16 of the high voltage control device 11 constitutes a discharge circuit for discharging the high voltage applied to the electrode cylinder 36 to lower the charge.
- the HV cascode 16 performs discharge control of the high voltage (HV) applied to the electrode cylinder 36 according to the cascode control signal from the HV discharge controller 15, and prevents excess charge from remaining in the electrode cylinder 36 at the time of discharge.
- the potential of the electrode cylinder 36 is lowered early with high responsiveness.
- the cascode control signal output from the HV discharge controller 15 is output during time t3 to t4, for example, as indicated by a characteristic line 19 shown in FIG.
- a characteristic line 20 shown in FIG. 4 is, for example, a high voltage measurement value from the high voltage monitor 12 and is output during time t1 to t4.
- the HV charge controller 13 and the HV discharge controller 15 of the high voltage controller 11 control the transformer 14 and the HV cascode 16 in parallel (in parallel) so that the transformer 14 and the HV cascode 16 do not operate simultaneously. ing. Therefore, after the transformer control signal (characteristic line 18) is output for time t1 to t3, the cascode control signal (characteristic line 19) is output for time t3 to t4.
- the HV charge controller 13 and the HV discharge controller 15 are separate controllers, but may be one controller using a high-speed controller.
- the HV charge controller 13 is configured, for example, as an analog controller composed of an electric circuit not involving software or the like.
- the HV discharge controller 15 is constituted by, for example, a digital controller having a central processing unit (CPU) and performing control via software.
- the HV charge controller 13 composed of an analog controller controls the analog control signal (the high voltage command value (high voltage request) output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12 Transformer control signal). This signal is sent to the transformer 14 which generates a high voltage proportional to the transformer control signal.
- the HV discharge controller 15 receives the high voltage command value (high voltage request) and the high voltage measurement value in parallel with the HV charge controller 13 and calculates a digital signal (cascode control signal). This signal is converted to an analog signal and sent to the HV cascode 16.
- the HV discharge controller 15 sends a cascode control signal to the HV cascode 16.
- the HV discharge controller 15 includes, for example, a digital-analog converter or a PWM output + demodulation device.
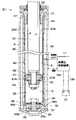
- the configuration of the damping force adjustable shock absorber 21 (that is, the ER damper 21) constituting the main part of the suspension device 4 will be described with reference to FIG. 1 and FIG.
- one end side of the ER damper 21 in the axial direction is referred to as the “lower end” side
- the other end side in the axial direction is referred to as the “upper end” side
- the other end side in the axial direction may be the “lower end” side.
- the ER damper 21 is a damping force variable shock absorber that damps vertical movement of the vehicle body 1 and the wheel 2.
- the ER damper 21 is configured as a damping force adjustable semi-active damper using a liquid electro-rheological fluid 22 as a working fluid sealed inside.
- Electrorheological fluid (ERF: Electro Rheological Fluid) 22 is a functional fluid whose property (viscosity) changes in response to an externally applied electric field (voltage).
- the electro-rheological fluid 22 (hereinafter referred to as the ER fluid 22) is prepared by mixing (dispersing) a base oil (base oil) comprising, for example, silicone oil etc. with the base oil, and the viscosity can be changed according to the change of the electric field. And particles (fine particles) to be increased or decreased.
- the ER fluid 22 has its viscosity increased or decreased according to the applied voltage, and the flow resistance (damping force) changes.
- the ER damper 21 is configured to include an inner cylinder 23, an outer cylinder 24, a piston 27, a piston rod 30, a bottom valve 32, an electrode cylinder 36 and the like.
- the inner cylinder 23 and the outer cylinder 24 constitute a cylinder, and an ER fluid 22 is enclosed in the cylinder.
- the ER fluid 22 enclosed is shown as colorless and transparent.
- the inner cylinder 23 is formed as a cylindrical cylinder extending in the axial direction.
- a piston rod 30 is inserted into the inner cylinder 23.
- An outer cylinder 24 and an electrode cylinder 36 are coaxially provided on the outer side of the inner cylinder 23.
- a plurality of (for example, 4 to 8) oil holes 23A, which are always communicated with an interelectrode passage 39 described later, are formed in the inner cylinder 23 as circumferential holes in the radial direction. That is, the rod side oil chamber B in the inner cylinder 23 is in communication with the interelectrode passage 39 through the oil hole 23A.
- the outer cylinder 24 forms an outer shell of the ER damper 21 and is formed as a cylindrical body.
- the outer cylinder 24 is provided radially outward of the electrode cylinder 36, and the reservoir chamber A is formed between the outer cylinder 24 and the electrode cylinder 36.
- the outer cylinder 24 is a closed end whose lower end side is closed by the bottom cap 25.
- the upper end side of the outer cylinder 24 is an open end.
- a seal member 26 is provided on the open end side of the outer cylinder 24 to seal the space between the piston rod 30 and the air- and liquid-tight.
- An annular reservoir chamber A serving as a reservoir is formed between the inner cylinder 23 and the outer cylinder 24 (more specifically, between the electrode cylinder 36 and the outer cylinder 24).
- a gas to be a working gas is enclosed in the reservoir chamber A, together with the ER fluid 22, a gas to be a working gas is enclosed.
- This gas may be air at atmospheric pressure, or a gas such as compressed nitrogen gas may be used.
- the gas in the reservoir chamber A is compressed to compensate for the approach volume of the piston rod 30 when the piston rod 30 contracts (contracts).
- the piston 27 is provided slidably in the inner cylinder 23.
- the piston 27 defines the inside of the inner cylinder 23 into a rod side oil chamber B as a first chamber and a bottom side oil chamber C as a second chamber.
- a plurality of oil passages 27A, 27B enabling communication between the rod side oil chamber B and the bottom side oil chamber C are formed on the piston 27 so as to be separated from each other in the circumferential direction.
- the ER damper 21 has a uniflow structure. Therefore, the ER fluid 22 in the inner cylinder 23 travels from the rod side oil chamber B (that is, the oil hole 23A of the inner cylinder 23) to the interelectrode passage 39 in both the compression stroke and the expansion stroke of the piston rod 30. It flows in one direction (that is, in the direction of an arrow F shown by a two-dot chain line in FIG. 2).
- a compression side check valve 28 is provided on the upper end surface of the piston 27.
- the contraction side check valve 28 opens when the piston 27 slides downward in the inner cylinder 23 in the contraction stroke of the piston rod 30, and closes at other times.
- the contraction-side check valve 28 allows the oil (ER fluid 22) in the bottom-side oil chamber C to flow in the respective oil passages 27A toward the rod-side oil chamber B, in the opposite direction to this. Stop the fluid from flowing.
- the lower end surface of the piston 27 is provided with a disk valve 29 on the extension side.
- the pressure in the rod side oil chamber B exceeds the relief set pressure when the piston 27 slides and displaces upward in the inner cylinder 23 in the extension stroke (extension stroke) of the piston rod 30 on the extension side disk valve 29. And the pressure at this time is relieved to the bottom side oil chamber C side via each oil passage 27B.
- the lower end of the piston rod 30 is connected (fixed) to the piston 27 in the inner cylinder 23, and the upper end is extended to the outside of the inner cylinder 23 and the outer cylinder 24 through the rod side oil chamber B.
- the upper end side of the piston rod 30 protrudes to the outside through the rod guide 31.
- the rod guide 31 is a member for guiding the piston rod 30 axially slidably on the inner peripheral side thereof.
- a bottom valve 32 is provided on the lower end side of the inner cylinder 23.
- the bottom valve 32 serves to connect and shut off the bottom side oil chamber C and the reservoir chamber A.
- the bottom valve 32 is configured to include a valve body 33, an expansion side check valve 34, and a disc valve 35.
- the valve body 33 defines the reservoir chamber A and the bottom side oil chamber C between the outer cylinder 24, the bottom cap 25 and the inner cylinder 23.
- oil passages 33A and 33B enabling communication between the reservoir chamber A and the bottom side oil chamber C are formed at intervals in the circumferential direction.
- the expansion side check valve 34 is provided, for example, on the upper surface side of the valve body 33.
- the extension check valve 34 opens when the piston 27 slides upward in the extension stroke of the piston rod 30, and closes otherwise.
- the expansion side check valve 34 allows the oil (ER fluid 22) in the reservoir chamber A to flow in the respective oil passages 33A toward the bottom side oil chamber C, and the oil in the opposite direction to this. Stop the flow.
- the disc valve 35 on the reduction side is provided on the lower surface side of the valve body 33.
- the reduction-side disk valve 35 opens when the pressure in the bottom-side oil chamber C exceeds the relief setting pressure when the piston 27 slides downward in the reduction stroke of the piston rod 30, and the pressure at this time Are relieved to the reservoir chamber A side via each oil passage 33B.
- an electrode cylinder 36 formed of an intermediate cylinder (pressure pipe) extending in the axial direction is provided between the inner cylinder 23 and the outer cylinder 24, an electrode cylinder 36 formed of an intermediate cylinder (pressure pipe) extending in the axial direction is provided.
- the electrode cylinder 36 is supported by the rod guide 31 and the valve body 33 via holding members 37 and 38.
- the holding members 37 and 38 are formed of, for example, an electrically insulating material (isolator).
- the upper holding member 37 keeps the inner cylinder 23, the rod guide 31 and the electrode cylinder 36 in an electrically insulated state.
- the lower holding member 38 keeps the inner cylinder 23, the valve body 33, and the electrode cylinder 36 in an electrically insulated state.
- the lower holding member 38 is formed with a plurality of oil passages 38A that allow the interelectrode passage 39 to communicate with the reservoir chamber A.
- the electrode cylinder 36 is disposed as an intermediate cylinder between the inner cylinder 23 and the outer cylinder 24.
- the electrode cylinder 36 is formed using a conductive material, and constitutes a cylindrical positive (plus side) electrode. That is, a high voltage (HV) is applied to the electrode cylinder 36 from the high voltage controller 11.
- the inner cylinder 23 radially opposed to the electrode cylinder 36 constitutes a cylindrical negative (minus side) electrode, and is electrically connected to the outer cylinder 24 via the valve body 33 and the like.
- an annular inter-electrode passage 39 is formed extending in the axial direction and in communication with the rod side oil chamber B via the plurality of oil holes 23A. Inside the interelectrode passage 39, the ER fluid 22 flows in one direction by the sliding (movement) of the piston 27.
- a partition member 40 is provided which partitions the inter-electrode passage 39 through which the ER fluid 22 flows (guides the flow of the ER fluid 22).
- the partition member 40 is attached to the outer peripheral surface of the inner cylinder 23 and the inner peripheral surface of the electrode cylinder 36 so as not to be relatively rotatable.
- the partition member 40 is a flow path forming member for guiding the ER fluid 22 not only in the axial direction but also in the circumferential direction between the inner cylinder 23 and the electrode cylinder 36.
- the inter-electrode passage 39 through which the ER fluid 22 flows can be made into one or a plurality of spiral or meandering passages (flow passages) having a circumferentially extending portion.
- the overall length of the interelectrode passage 39 (the length of the flow passage from the oil hole 23A to the oil passage 38A) can be increased as compared with the passage extending linearly in the axial direction.
- the ER fluid 22 in the interelectrode passage 39 moves along the interelectrode passage as the piston rod 30 moves back and forth in the inner cylinder 23 (that is, while the contraction and extension strokes are repeated). It flows from the upper side to the lower side in the axial direction of 39. Then, the ER fluid 22 flowing into the interelectrode passage 39 flows out from the lower end side of the electrode cylinder 36 to the reservoir chamber A via the oil passage 38A of the holding member 38. At this time, in the interelectrode passage 39, an electric field (potential difference) corresponding to the high voltage applied to the electrode cylinder 36 is generated, so the viscosity of the ER fluid 22 is variably adjusted according to the electric field strength.
- the ER damper 21 generates an electric field (potential difference) in the interelectrode passage 39 between the inner cylinder 23 and the electrode cylinder 36, and the viscosity of the ER fluid 22 passing through the interelectrode passage 39 corresponds to the electric field.
- the generated damping force can be variably controlled (adjusted).
- the viscosity of the ER fluid 22 is increased or decreased according to the electric field strength (potential difference) between the inner cylinder 23 and the electrode cylinder 36, and the higher the high voltage (HV) applied from the high voltage control device 11, the generated damping force becomes a hard property and increases.
- the ER damper 21 changes the characteristic (damping force characteristic) of the generated damping force to a high voltage according to the increase or decrease of the high voltage (HV) applied to the electrode cylinder 36 provided in the portion where the ER fluid 22 flows.
- the adjustment can be made continuously between the time hard characteristics (hard characteristics) and the low voltage soft characteristics (soft characteristics).
- the ER damper 21 does not necessarily have to change the damping force characteristics continuously, and may be configured to be adjustable in two or more stages.
- the suspension control device has the configuration as described above. Next, the damping force characteristic of the ER damper 21 is variably controlled using the command control device 9 of the control device 8 and the high voltage control device 11 The process to be performed will be described.
- the command control device 9 receives a detection signal corresponding to the sprung acceleration from the sprung acceleration sensor 6 and a detection signal corresponding to the unsprung acceleration from the unsprung acceleration sensor 7. At this time, the command control device 9 calculates a target damping force from the sprung acceleration and the unsprung upper speed using, for example, a skyhook control law, and calculates a target voltage necessary to generate the target damping force. Do. Then, the command control device 9 outputs a high voltage command value corresponding to the target damping force (target voltage) to the high voltage control device 11.
- a high voltage measurement value from, for example, the high voltage monitor 12 is input to the high voltage control device 11.
- the high voltage measurement value is obtained by monitoring (monitoring) a high voltage which is boosted by the high voltage control device 11 and applied to the electrode cylinder 36.
- This high voltage measurement value is for feedback control of the high voltage control device 11.
- Used for The high voltage monitor 12 can be constituted by, for example, a high voltage detector provided on the output side of the high voltage control device 11, and in FIG. 1, one means for clearly indicating the high voltage measurement value.
- the high voltage monitor 12 is illustrated in FIG.
- the high voltage command value output from the command control unit 9 to the high voltage control unit 11 is output as a high level during time t1 to t2, as shown by the characteristic line 17 shown in FIG. 4, for example.
- the HV charge controller 13 of the high voltage control device 11 outputs a transformer control signal over time t1 to t3 as shown by the characteristic line 18.
- transformer 14 performs, for example, transformation control so that the DC voltage from battery 10 is boosted, and supplies (outputs) the boosted high voltage (HV) to electrode cylinder 36 of ER damper 21. . That is, the HV charge controller 13 receives the high voltage command value (high voltage request), and when the request is increasing, boosts the DC voltage until the output voltage (HV) of the transformer 14 reaches the required voltage value. Perform transformation control.
- the transformer 14 stops the transformer control for boosting to generate energy.
- the HV discharge controller 15 of the high voltage control device 11 performs discharge control of the HV cascode 16 in order to dissipate the charge energy applied to the electrode cylinder 36 of the ER damper 21 and stored in the ER fluid 22. Decrease the voltage.
- the HV discharge controller 15 controls cascode control as shown by the characteristic line 19 in FIG. 4 based on the high voltage command value output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12. The signal is calculated and this cascode control signal is output to the HV cascode 16.
- the HV cascode 16 performs discharge control of the high voltage (HV) applied to the electrode cylinder 36 according to the cascode control signal.
- the HV discharge controller 15 of the high voltage control device 11 uses the high voltage command value (high voltage request) output from the command control device 9 and the high voltage measurement value from the high voltage monitor 12 as input signals.
- a cascode control signal is calculated as indicated by the characteristic line 19 in FIG. 4 according to a predetermined cascode control algorithm.
- the electric cylinder 36 (ER fluid 22) of the ER damper 21 receives a high voltage electric field Granted.
- the cascode control signal is zero as indicated by the characteristic line 19, and the HV cascode 16 is in the off state where the discharge control is stopped.
- the transformer control signal (characteristic line 18) increases in value as the demand for the high voltage command value increases.
- the transformer control signal of the characteristic line 18 Between times t2 and t3, a delay time to reach the minimum value (ie, delay time ⁇ T in FIG. 4) occurs.
- the HV discharge controller 15 of the high voltage control device 11 calculates a cascode control signal for reducing the high voltage after the delay time ⁇ T as shown by the characteristic line 19.
- the cascode control signal becomes zero at time t4 as indicated by the characteristic line 19, and at this time, the high voltage measurement value (characteristic line 20) becomes the minimum value.
- control is started with a predetermined algorithm according to the magnitude of the deviation between the high voltage command value in the HV discharge controller 15 and the measured value.
- control of cascode is started after a predetermined delay time has elapsed.
- time t2 to t5 is required to reduce the high voltage to the minimum value as shown by a characteristic line 100 shown by a two-dot chain line in FIG. That is, in the prior art ER damper, since the electro-rheological fluid sealed inside has a large time constant, the high voltage (HV) is applied to the electrode that applies an electric field to the electro-rheological fluid, after applying the high voltage (HV) Control by discharging the electrode from the electrode, it is difficult for the charge to be removed, and it takes an extra time, which causes the response of damping force control to be deteriorated.
- HV high voltage
- a transformer control signal is output to perform charging control of high voltage (HV) applied to electrode cylinder 36 of ER damper 21 based on the high voltage command value in high voltage control device 11.
- the voltage is applied to the electrode cylinder 36 based on the high voltage command value and the transformer 14 that performs transformation control of the high voltage applied to the electrode cylinder 36 according to the transformer control signal from the HV charge controller 13 and the HV charge controller 13
- the HV discharge controller 15 outputs a cascode control signal to perform high voltage discharge control, and the HV cascode 16 performs discharge control of high voltage applied to the electrode cylinder 36 according to the cascode control signal from the HV discharge controller 15 Configured.
- the HV discharge controller 15 of the high voltage control device 11 outputs a cascode control signal (characteristic line 19 in FIG. 4) to the HV cascode 16 to output a high voltage (HV) from the electrode cylinder 36.
- the charge of the high voltage (HV) is easily released from the electrode cylinder 36 when the discharge control is performed.
- the high voltage measurement value detected by the high voltage monitor 12 has an early minimum value between times t3 and t4 as shown by the characteristic line 20 in FIG. 4, and the charge is discharged from the electrode cylinder 36 at time t4. Get out.
- the control for discharging the charge from the electrode cylinder 36 can be completed at time t4 earlier than time t5 by the characteristic line 100 of the prior art, and the responsiveness of damping force control is improved. be able to. That is, application of high voltage to the electrode cylinder 36 of the ER damper 21 and discharge control can be performed with high responsiveness, and the reliability and stability of damping force control can be enhanced.
- the high voltage control device 11 is configured to control the transformer 14 and the HV cascode 16 in parallel (in parallel) so that the transformer 14 and the HV cascode 16 do not operate at the same time.
- the transformer 14 and the HV cascode 16 do not operate at the same time, and the time difference between the supply of high voltage (i.e., electrical energy) from the transformer 14 and the discharge control (dissipation of energy) by the HV cascode 16 Can be done efficiently.
- the ER damper 21 of the suspension device 4 is mounted vertically on a vehicle such as a car.
- the present invention is not limited to this.
- the ER damper 21 may be configured to be attached to a vehicle such as a railway vehicle in a state of being placed horizontally. That is, the ER damper 21 can be installed in a desired direction in accordance with the object to be attached, for example, by arranging the ER damper 21 in an inclined manner in a range that does not cause aeration.
- suspension control device based on the embodiment described above, for example, one having an aspect described below can be considered.
- a suspension control device comprises a vehicle behavior detection unit for detecting the behavior of the vehicle, a damping force adjustable shock absorber provided between two members of the vehicle moving relative to each other, and a detection result of the vehicle behavior detection unit. And a controller for adjusting the damping force of the damping force adjustable shock absorber.
- the damping force adjustable shock absorber includes a cylinder in which an electrorheological fluid is sealed, a piston slidably inserted in the cylinder, and a piston rod connected to the piston and extending outside the cylinder. And an electrode which is provided at a portion where the flow of the electrorheological fluid is generated by the movement of the piston in the cylinder, and which applies an electric field to the electrorheological fluid.
- the control device determines a high voltage command value for variably adjusting the damping force based on the detection result of the vehicle behavior detection unit, and the high voltage command output from the command control device And a high voltage control device for feedback controlling a high voltage applied to the electrode based on a value.
- the high voltage control device comprises: an HV charge controller for outputting a transformer control signal for performing charge control of high voltage applied to the electrode; and HV charge control for transforming the high voltage applied to the electrode.
- an HV cascode for performing the discharge control according to the cascode control signal from the HV discharge controller.
- the high voltage control device controls the transformer and the HV cascode in parallel so that the transformer and the HV cascode do not operate simultaneously.
- the HV charge controller is an analog controller
- the HV discharge controller is a digital controller.
- the HV charge controller and the HV discharge controller are integrally formed as a single controller.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- Acoustics & Sound (AREA)
- Aviation & Aerospace Engineering (AREA)
- Electromagnetism (AREA)
- Vehicle Body Suspensions (AREA)
- Fluid-Damping Devices (AREA)
- Vibration Prevention Devices (AREA)
Abstract
ERダンパにおける減衰力制御の応答性を向上できるようにする。 制御装置は、車両挙動検出部の検出結果に基づいて減衰力を可変に調整するための高電圧指令値を求める指令制御装置と、指令制御装置から出力される高電圧指令値に基づいて電極に印加される高電圧をフィードバック制御する高電圧制御装置と、を備える。高電圧制御装置は、電極に印加される高電圧の充電制御を行うための変圧器制御信号を出力するHV充電コントローラと、電極に印加される高電圧の変圧制御をHV充電コントローラからの変圧器制御信号に従って行う変圧器と、電極に印加される高電圧の放電制御を行うためのカスコード制御信号を出力するHV放電コントローラと、電極に印加される高電圧の放電制御をHV放電コントローラからのカスコード制御信号に従って行うHVカスコードと、を備える。
Description
本発明は、例えば4輪自動車等の車両に搭載されるサスペンション制御装置に関する。
4輪自動車等の車両には車体(ばね上)側と各車輪(ばね下)側との間に、例えばサスペンションとしての減衰力調整式緩衝器(ダンパ)が設けられている。この種の従来技術には、シリンダ内に電気粘性流体(ERF:Electro Rheological Fluid)を封入した状態で、高電圧による電界を付与することにより発生減衰力を可変に制御する構成とした減衰力調整式緩衝器(ERダンパ)が知られている(例えば、特許文献1参照)。
ところで、従来技術のERダンパは、内部に封入した電気粘性流体が大きな時定数をもっている。このため、電気粘性流体に電界をかける電極に対し、高電圧(HV)を印加したり、この高電圧(HV)を電極から放電させたりする制御には余分な時間がかかり、減衰力制御の応答性を向上することが難しいという問題がある。
本発明の目的は、減衰力制御の応答性を向上することができるようにしたサスペンション制御装置を提供することにある。
本発明の一実施形態によれば、サスペンション制御装置が提供される。このサスペンション制御装置は、車両の挙動を検出する車両挙動検出部と、前記車両の相対移動する2部材間に設けられた減衰力調整式緩衝器と、前記車両挙動検出部の検出結果に基づいて前記減衰力調整式緩衝器の減衰力を調整する制御装置と、を備える。前記減衰力調整式緩衝器は、電気粘性流体が封入されたシリンダと、該シリンダ内に摺動可能に挿入されたピストンと、該ピストンに連結されて前記シリンダの外部に延出するピストンロッドと、前記シリンダ内での前記ピストンの移動によって前記電気粘性流体の流れが生じる部分に設けられ、前記電気粘性流体に電界をかける電極と、を備える。
前記制御装置は、前記車両挙動検出部の前記検出結果に基づいて前記減衰力を可変に調整するための高電圧指令値を求める指令制御装置と、前記指令制御装置から出力される前記高電圧指令値に基づいて前記電極に印加される高電圧をフィードバック制御する高電圧制御装置と、を備える。前記高電圧制御装置は、前記電極に印加される高電圧の充電制御を行うための変圧器制御信号を出力するHV充電コントローラと、前記電極に印加される前記高電圧の変圧制御を前記HV充電コントローラからの前記変圧器制御信号に従って行う変圧器と、前記電極に印加される前記高電圧の放電制御を行うためのカスコード制御信号を出力するHV放電コントローラと、前記電極に印加される前記高電圧の放電制御を前記HV放電コントローラからの前記カスコード制御信号に従って行うHVカスコードと、を備える。
本発明の一実施形態によるサスペンション制御装置は、減衰力制御を行うときの応答性を向上することができる。
以下、本発明の実施の形態によるサスペンション制御装置を、4輪自動車に搭載した場合を例に挙げ、添付図面の図1ないし図4に従って詳細に説明する。
図1において、車体1は、車両のボディを構成している。車体1の下側には、車体1と共に車両を構成する車輪2(例えば、左,右の前輪と左,右の後輪を総称して車輪2という)が設けられている。この車輪2は、タイヤ3を含んで構成され、タイヤ3は、路面の細かい凹凸を吸収するばねとして作用する。
サスペンション装置4は、車両の相対移動する2部材間(例えば、車体1と車輪2との間)に設けられている。サスペンション装置4は、懸架ばね5(以下、ばね5という)と、該ばね5と並列になって前記2部材間(車体1と車輪2との間)に設けられた後述の減衰力調整式緩衝器21(以下、ERダンパ21という)とを含んで構成されている。なお、図1中では、1組のサスペンション装置4を車体1と車輪2との間に設けた場合を例示している。しかし、サスペンション装置4は、例えば4輪の車輪2と車体1との間に個別に独立して合計4組設けられるもので、このうちの1組のみを図1では模式的に示している。
車体1側にはばね上加速度センサ6が設けられている。このばね上加速度センサ6は、例えば後述するERダンパ21の近傍となる位置で車体1に取付けられている。ばね上加速度センサ6は、所謂ばね上側となる車体1側で上,下方向の振動加速度を検出し、その検出信号(即ち、ばね上加速度の信号)を指令制御装置9に出力する。一方、車両の車輪2側にはばね下加速度センサ7が設けられている。このばね下加速度センサ7は、所謂ばね下側となる車輪2側で上,下方向の振動加速度を検出し、その検出信号(即ち、ばね下加速度の信号)を指令制御装置9に出力する。
ここで、ばね上加速度センサ6とばね下加速度センサ7は、車両の挙動を検出する車両挙動検出部(より具体的には、車両の上,下方向の運動に関する状態量を検出する上下運動検出部)を構成している。なお、車両挙動検出部は、ERダンパ21の近傍に設けたばね上加速度センサ6とばね下加速度センサ7とを含んで必ずしも構成する必要はない。例えば、ばね上加速度センサ6だけで車両挙動検出部を構成することもできる。また、車両挙動検出部は、車輪2に対する車体1の上,下方向の高さ位置(車高)を検出する車高センサ(図示せず)により構成してもよい。
さらには、車輪2の回転速度を検出する車輪速センサ(図示せず)等、加速度センサ6,7、前記車高センサ以外の車両の挙動(状態量)を検出するセンサにより車両挙動検出部を構成してもよい。この場合、例えば1個のばね上加速度センサ6の情報(加速度)と車輪速センサの情報(車輪速)から各車輪2毎の上下運動を推定することで、車両の上下運動を車両挙動として検出する構成としてもよい。
制御装置8は、前記車両挙動検出部(例えば、加速度センサ6,7)の検出結果に基づいて減衰力調整式緩衝器21(即ち、ERダンパ21という)の発生減衰力を可変に調整するための制御装置である。この制御装置8は、図1中に示すように、指令制御装置9と後述の高電圧制御装置11とを備えている。制御装置8の指令制御装置9は、例えば車体1の車室内等に配設され、高電圧制御装置11は、後述するERダンパ21の外筒24に図2に示す如く付設される。高電圧制御装置11は、外筒24の径方向外側に着脱可能に取付けられるHVボックスでもある。
指令制御装置9は、サスペンション装置用のECU(Electronic Control Unit)と呼ばれるもので、例えばマイクロコンピュータを含んで構成されている。指令制御装置9は、その入力側が前記車両挙動検出部(例えば、加速度センサ6,7)に接続され、出力側は高電圧制御装置11に接続されている。これらの接続には、例えばデータ通信を行う回線網であるCAN(Controller Area Network)からなる通信回線を用いることができる。
指令制御装置9は、前記車両挙動検出部(例えば、加速度センサ6,7)の検出結果に基づいて前記減衰力を可変に調整するための高電圧指令値を求める。即ち、指令制御装置9は、ばね上加速度センサ6とばね下加速度センサ7とから入力された車両挙動情報により、例えばスカイフック制御則等を用いてERダンパ21の減衰力を可変に調整するための高電圧指令値を算出し、この高電圧指令値を高電圧制御装置11に出力する。即ち、指令制御装置9と高電圧制御装置11とからなる制御装置8は、減衰力可変ダンパであるERダンパ21で発生する減衰力を、前記車両挙動検出部の検出結果に基づいて可変に調整するように制御する。
図1に示すように、バッテリ10は、ERダンパ21(例えば、後述の電極筒36)に高電圧を印加するための電源となっている。バッテリ10は、例えば車両の補機用バッテリとなる12Vの車載バッテリ(および、必要に応じて車載バッテリの充電を行うオルタネータ)により構成されている。バッテリ10は、正極側が高電圧制御装置11を介してERダンパ21の電極筒36に接続され、負極側はERダンパ21のダンパシェルとなる外筒24に接続されている。なお、バッテリ10は、高電圧制御装置11に限らず、例えば指令制御装置9等の電源でもあるが、図面の簡略化のために図示は省略している。また、ERダンパ21の電源は、例えば、走行用の電動モータ(駆動モータ)が搭載されたハイブリッド自動車や電気自動車の場合、車両駆動用の大容量バッテリ(図示せず)を用いることもできる。
高電圧制御装置11は、ERダンパ21(例えば、電極筒36)に印加する高電圧を可変に制御する装置である。このために、高電圧制御装置11は、直流電力線を構成するバッテリ線(batt線)10Aとグランド線(GND線)10Bとを介して電源となるバッテリ10に接続されている。高電圧制御装置11は、指令制御装置9から出力される前記高電圧指令値と高電圧モニタ12からの高電圧測定値とに基づいて、ERダンパ21の電極筒36に印加する高電圧をフィードバック制御するものである。
高電圧制御装置11は、その入力側が指令制御装置9および高電圧モニタ12等に接続され、出力側はERダンパ21の電極筒36に接続されている。高電圧モニタ12は、高電圧制御装置11で昇圧された高電圧をモニタ(監視または検出)し、これを高電圧測定値として高電圧制御装置11にフィードバック制御のために出力する。なお、高電圧モニタ12は、例えば高電圧制御装置11の出力側に設けた高電圧の検出器等により構成してもよい。
図3に示すように、高電圧制御装置11は、HV充電コントローラ13、変圧器14、後述のHV放電コントローラ15およびHVカスコード16を含んで構成されている。このうち、HV充電コントローラ13は、指令制御装置9から出力される高電圧指令値と高電圧モニタ12からの高電圧測定値とに基づいて、ERダンパ21の電極筒36に印加する高電圧の充電制御を行うための変圧器制御信号を演算して求め、この変圧器制御信号を変圧器14に出力する。この変圧器14は、HV充電コントローラ13から出力される前記変圧器制御信号に従って電極筒36に印加する高電圧の変圧制御を行うものである。
ここで、指令制御装置9から出力される高電圧指令値は、例えば図4に示す特性線17の如く、時間t1~t2の間にハイレベルとなって出力される。このとき、HV充電コントローラ13は、特性線18の如く時間t1~t3にわたって変圧器制御信号を出力する。変圧器14は、HV充電コントローラ13から出力される前記変圧器制御信号に従って、例えばバッテリ10からの直流電圧を昇圧させるように変圧制御し、昇圧された高電圧(HV)をERダンパ21の電極筒36に供給(出力)する。
高電圧制御装置11のHV放電コントローラ15は、ERダンパ21の電極筒36に印加される電圧を降圧させるように放電制御を行う。即ち、HV放電コントローラ15は、指令制御装置9から出力される高電圧指令値と高電圧モニタ12からの高電圧測定値とに基づいて、電極筒36に印加される高電圧の放電制御を行うためのカスコード制御信号を演算して求め、このカスコード制御信号をHVカスコード16に出力する。
高電圧制御装置11のHVカスコード16は、電極筒36に印加された高電圧を放電して電荷を下げるための放電回路を構成している。このHVカスコード16は、HV放電コントローラ15からの前記カスコード制御信号に従って電極筒36に印加された高電圧(HV)の放電制御を行い、放電時に電極筒36に余分な電荷が残るのを防ぐため、電極筒36の電位を早期に高い応答性で低下させるものである。
ここで、HV放電コントローラ15から出力されるカスコード制御信号は、例えば図4に示す特性線19の如く、時間t3~t4の間に出力される。図4に示す特性線20は、例えば高電圧モニタ12からの高電圧測定値であり、時間t1~t4の間に出力される。高電圧制御装置11のHV充電コントローラ13とHV放電コントローラ15とは、変圧器14とHVカスコード16とが同時に作動しないように、変圧器14とHVカスコード16とを並行(並列的)に制御している。このため、変圧器制御信号(特性線18)が時間t1~t3にわたって出力された後に、カスコード制御信号(特性線19)が時間t3~t4の間に出力される。なお、本実施の形態では、HV充電コントローラ13とHV放電コントローラ15とは別のコントローラとしているが、高速コントローラを用いて、1つのコントローラとすることもできる。
HV充電コントローラ13は、例えばソフトウエア等を介さない電気回路からなるアナログコントローラとして構成されている。一方、HV放電コントローラ15は、例えば中央演算装置(CPU)を有しソフトウエアを介した制御を行うデジタルコントローラにより構成されている。
換言すると、アナログコントローラからなるHV充電コントローラ13は、指令制御装置9から出力される高電圧指令値(高電圧要求)と高電圧モニタ12からの高電圧測定値との差に従って、アナログ制御信号(変圧器制御信号)発生させる。この信号は、変圧器制御信号と比例した高電圧を発生させる変圧器14へと送られる。
一方、HV放電コントローラ15は、HV充電コントローラ13と並行して前記高電圧指令値(高電圧要求)と前記高電圧測定値とを受信し、デジタル信号(カスコード制御信号)を演算する。この信号はアナログ信号に変換されてHVカスコード16に送られる。HV放電コントローラ15は、カスコード制御信号をHVカスコード16に送る。HV放電コントローラ15には、例えば、デジタル-アナログコンバータ、またはPWM出力+復調(デモデュレーション)装置等が含まれている。
次に、サスペンション装置4の主要部を構成する減衰力調整式緩衝器21(即ち、ERダンパ21)の構成について、図1と図2を参照しつつ説明する。なお、以下の説明では、ERダンパ21の軸方向の一端側を「下端」側とし、軸方向の他端側を「上端」側として記載するが、ERダンパ21の軸方向の一端側を「上端」側とし、軸方向の他端側を「下端」側としてもよい。
ERダンパ21は、車体1と車輪2の上下動を減衰させる減衰力可変の緩衝器である。このERダンパ21は、内部に封入する作動流体として液体の電気粘性流体22を用いた減衰力調整式のセミアクティブダンパとして構成されている。電気粘性流体(ERF:Electro Rheological Fluid)22は、外部から付与された電界(電圧)に応じて性状(粘性)が変化する機能性流体である。電気粘性流体22(以下、ER流体22という)は、例えば、シリコンオイル等からなる基油(ベースオイル)と、該基油に混合して調製(分散)され前記電界の変化に応じて粘性を可変に増減させる粒子(微粒子)とにより構成されている。これにより、ER流体22は、印加される電圧に応じて粘度が増減され、流動抵抗(減衰力)が変化する。
図2において、ERダンパ21は、内筒23、外筒24、ピストン27、ピストンロッド30、ボトムバルブ32、電極筒36等を含んで構成されている。内筒23と外筒24はシリンダを構成し、このシリンダ内には、ER流体22が封入されている。なお、図1および図2では、封入されているER流体22を無色透明で表している。
内筒23は、軸方向に延びる円筒状の筒体として形成されている。内筒23の内部には、ピストンロッド30が挿入されている。内筒23の外側には、外筒24および電極筒36が同軸となるように設けられている。内筒23には、後述の電極間通路39に常時連通する油穴23Aが径方向の横孔として周方向に離間して複数(例えば、4~8個)形成されている。即ち、内筒23内のロッド側油室Bは、油穴23Aによって電極間通路39と連通している。
外筒24は、ERダンパ21の外殻をなすもので、円筒体として形成されている。外筒24は、電極筒36の径方向外側に設けられており、該電極筒36との間にリザーバ室Aを形成している。この場合、外筒24は、その下端側がボトムキャップ25により閉塞された閉塞端となっている。外筒24の上端側は、開口端となっている。外筒24の開口端側には、ピストンロッド30との間を気,液密に封止(シール)するシール部材26が設けられている。
内筒23と外筒24との間(より具体的には、電極筒36と外筒24との間)には、リザーバとなる環状のリザーバ室Aが形成されている。リザーバ室A内には、ER流体22と共に、作動気体となるガスが封入されている。このガスは、大気圧状態の空気であってもよく、また圧縮された窒素ガス等の気体を用いてもよい。リザーバ室A内のガスは、ピストンロッド30の縮小(縮み行程)時に、当該ピストンロッド30の進入体積分を補償すべく圧縮される。
ピストン27は、内筒23内に摺動可能に設けられている。ピストン27は、内筒23内を第1室となるロッド側油室Bと第2室となるボトム側油室Cとに画成している。ピストン27には、ロッド側油室Bとボトム側油室Cとを連通可能とする油路27A,27Bがそれぞれ複数個、周方向に互いに離間して形成されている。
ここで、ERダンパ21はユニフロー構造となっている。このため、内筒23内のER流体22は、ピストンロッド30の縮み行程と伸び行程との両行程で、ロッド側油室B(即ち、内筒23の油穴23A)から電極間通路39に向けて常に一方向(即ち、図2中に二点鎖線で示す矢印Fの方向)に流通する。ユニフロー構造を実現するため、ピストン27の上端面には縮み側逆止弁28が設けられている。この縮み側逆止弁28は、ピストンロッド30の縮小行程(縮み行程)でピストン27が内筒23内を下向きに摺動変位するときに開弁し、これ以外のときには閉弁する。縮み側逆止弁28は、ボトム側油室C内の油液(ER流体22)がロッド側油室Bに向けて各油路27A内を流通するのを許し、これとは逆向きに油液が流れるのを阻止する。
ピストン27の下端面には、伸長側のディスクバルブ29が設けられている。伸長側のディスクバルブ29は、ピストンロッド30の伸長行程(伸び行程)でピストン27が内筒23内を上向きに摺動変位するときに、ロッド側油室B内の圧力がリリーフ設定圧を越えると開弁し、このときの圧力を、各油路27Bを介してボトム側油室C側にリリーフする。
ピストンロッド30は、その下端が内筒23内でピストン27に連結(固定)され、その上端がロッド側油室Bを通って内筒23および外筒24の外部へ延出されている。この場合、ピストンロッド30の上端側は、ロッドガイド31を介して外部に突出している。ロッドガイド31は、その内周側でピストンロッド30を軸方向に摺動可能に案内(ガイド)する部材である。
内筒23の下端側にはボトムバルブ32が設けられている。このボトムバルブ32は、ボトム側油室Cとリザーバ室Aとを連通,遮断するものである。このため、ボトムバルブ32は、バルブボディ33と、伸び側逆止弁34と、ディスクバルブ35とを含んで構成されている。バルブボディ33は、外筒24、ボトムキャップ25と内筒23との間でリザーバ室Aとボトム側油室Cとを画成する。バルブボディ33には、リザーバ室Aとボトム側油室Cとを連通可能とする油路33A,33Bがそれぞれ周方向に間隔をあけて形成されている。
伸び側逆止弁34は、例えばバルブボディ33の上面側に設けられている。伸び側逆止弁34は、ピストンロッド30の伸長行程でピストン27が上向きに摺動変位するときに開弁し、これ以外のときには閉弁する。伸び側逆止弁34は、リザーバ室A内の油液(ER流体22)がボトム側油室Cに向けて各油路33A内を流通するのを許し、これとは逆向きに油液が流れるのを阻止する。
縮小側のディスクバルブ35はバルブボディ33の下面側に設けられている。縮小側のディスクバルブ35は、ピストンロッド30の縮小行程でピストン27が下向きに摺動変位するときに、ボトム側油室C内の圧力がリリーフ設定圧を越えると開弁し、このときの圧力を、各油路33Bを介してリザーバ室A側にリリーフする。
内筒23と外筒24との間には、軸方向に延びる中間筒(圧力管)からなる電極筒36が設けられている。この電極筒36は、ロッドガイド31とバルブボディ33とに対して保持部材37,38を介して支持されている。保持部材37,38は、例えば電気絶縁性材料(アイソレータ)により形成されている。上側の保持部材37は、内筒23およびロッドガイド31と電極筒36との間を電気的に絶縁した状態に保っている。下側の保持部材38は、内筒23およびバルブボディ33と電極筒36との間を電気的に絶縁した状態に保っている。下側の保持部材38には、電極間通路39をリザーバ室Aに対して連通させる複数の油路38Aが形成されている。
電極筒36は、内筒23と外筒24との間に中間筒として配設されている。電極筒36は、導電性材料を用いて形成され、筒状の正(プラス側)電極を構成している。即ち、電極筒36には、高電圧制御装置11から高電圧(HV)が印加される。電極筒36と径方向で対向する内筒23は、筒状の負(マイナス側)電極を構成し、外筒24とバルブボディ33等を介して電気的に接続されている。内筒23と電極筒36との間には、ロッド側油室Bと複数の油穴23Aを介して連通し軸方向に延びる環状の電極間通路39が形成されている。電極間通路39の内部では、ピストン27の摺動(移動)によってER流体22が一方向に流通する。
内筒23の外周と電極筒36の内周との間には、ER流体22が流通する電極間通路39を仕切る(ER流体22の流れを案内する)隔壁部材40が設けられている。この隔壁部材40は、内筒23の外周面と電極筒36の内周面とに対して相対回転不能に取付けられている。隔壁部材40は、内筒23と電極筒36との間でER流体22を軸方向だけでなく、周方向にも案内する流路形成部材である。これにより、ER流体22が流通する電極間通路39を、周方向に延びる部分を有する螺旋状または蛇行する1個または複数個の通路(流路)とすることができる。この場合には、軸方向に直線的に延びる通路と比較して、電極間通路39の全長(油穴23Aから油路38Aまでの流路の長さ)を長くすることができる。
ここで、電極間通路39内のER流体22は、ピストンロッド30が内筒23内を進退動するとき(即ち、縮み行程と伸び行程を繰返す間)に、この進退動に伴って電極間通路39の軸方向の上側から下側へと流通する。そして、電極間通路39内に流入したER流体22は、電極筒36の下端側から保持部材38の油路38Aを介してリザーバ室Aに流出してゆく。このとき、電極間通路39内では、電極筒36に印加される高電圧に応じた電界(電位差)が発生するため、ER流体22の粘度は、電界強度に従って可変に調整される。
即ち、ERダンパ21は、内筒23と電極筒36との間の電極間通路39内に電界(電位差)を発生させ、該電極間通路39を通過するER流体22の粘度を電界に応じて変化させることで、発生減衰力を可変に制御(調整)することができる。ER流体22の粘度は、内筒23と電極筒36との間の電界強度(電位差)に応じて増減され、高電圧制御装置11から印加される高電圧(HV)が大きい程、発生減衰力はハードな特性となって大きくなる。
換言すると、ERダンパ21は、ER流体22の流れが生じる部分に設けられた電極筒36に印加する高電圧(HV)の増減に応じて、発生減衰力の特性(減衰力特性)を高電圧時のハード(Hard)な特性(硬特性)と、低電圧時のソフト(Soft)な特性(軟特性)との間で連続的に調整することができる。なお、ERダンパ21は、減衰力特性を必ずしも連続的に変化させる必要はなく、2段階または3段階以上の複数段階で調整可能な構成としてもよい。
本実施の形態によるサスペンション制御装置は、上述の如き構成を有するもので、次に、制御装置8の指令制御装置9および高電圧制御装置11を用いてERダンパ21の減衰力特性を可変に制御する処理について説明する。
指令制御装置9には、車両の走行時にばね上加速度センサ6からばね上加速度に対応する検出信号が入力されると共に、ばね下加速度センサ7からばね下加速度に対応する検出信号が入力される。このとき、指令制御装置9は、例えばスカイフック制御則等を用いて、ばね上加速度とばね下上速度とから目標減衰力を演算し、目標減衰力を発生させるために必要な目標電圧を算出する。そして、指令制御装置9は、この目標減衰力(目標電圧)に対応した高電圧指令値を高電圧制御装置11に出力する。
また、高電圧制御装置11には、例えば高電圧モニタ12からの高電圧測定値が入力される。この高電圧測定値は、高電圧制御装置11で昇圧されて電極筒36に印加される高電圧をモニタ(監視)したもので、この高電圧測定値は高電圧制御装置11のフィードバック制御のために用いられる。なお、高電圧モニタ12は、例えば高電圧制御装置11の出力側に設けた高電圧の検出器等により構成することができ、図1中では、高電圧測定値を明示するための一つの手段として高電圧モニタ12を図示したものである。
指令制御装置9から高電圧制御装置11に出力される高電圧指令値は、例えば図4に示す特性線17の如く、時間t1~t2の間にハイレベルとなって出力される。このとき、高電圧制御装置11のHV充電コントローラ13は、特性線18の如く時間t1~t3にわたって変圧器制御信号を出力する。変圧器14は、この変圧器制御信号に従って、例えばバッテリ10からの直流電圧を昇圧させるように変圧制御し、昇圧された高電圧(HV)をERダンパ21の電極筒36に供給(出力)する。即ち、HV充電コントローラ13は、高電圧指令値(高電圧要求)を受取り、この要求が増加しているときには、変圧器14の出力電圧(HV)が要求電圧値に達するまで直流電圧を昇圧させる変圧制御を行う。
一方、高電圧指令値(高電圧要求)が減少するときには、変圧器14はエネルギを生成する昇圧のための変圧制御を止める。このとき、高電圧制御装置11のHV放電コントローラ15は、ERダンパ21の電極筒36に印加されER流体22に蓄えられた電荷エネルギを消散させるため、HVカスコード16の放電制御を行い、前記高電圧を減少させる。
このために、HV放電コントローラ15は、指令制御装置9から出力される高電圧指令値と高電圧モニタ12からの高電圧測定値とに基づいて、図4中の特性線19の如く、カスコード制御信号を演算し、このカスコード制御信号をHVカスコード16に出力する。HVカスコード16は、カスコード制御信号に従って電極筒36に印加された高電圧(HV)の放電制御を行う。
このように、高電圧制御装置11のHV放電コントローラ15は、指令制御装置9から出力される高電圧指令値(高電圧要求)と高電圧モニタ12からの高電圧測定値とを入力信号として用い、予め決められたカスコードの制御アルゴリズムに従って図4の特性線19の如くカスコード制御信号を演算する。
図4中の時間t1~t2の如く、指令制御装置9からの高電圧指令値(特性線17)が増加するとき、ERダンパ21の電極筒36(ER流体22)には高電圧の電界が付与される。この間は、特性線19の如くカスコード制御信号はゼロで、HVカスコード16は放電制御を停止したオフの状態である。この間、変圧器制御信号(特性線18)は、高電圧指令値の要求が増えるに従って信号値が増加する。
しかし、図4中の時間t2~t4の如く、特性線17の高電圧指令値(高電圧要求)が高電圧測定値(特性線20)よりも小さくなると、特性線18の変圧器制御信号が時間t2~t3間で、最小値に到達するまでの遅延時間(即ち、図4中の遅延時間ΔT)が生じる。高電圧制御装置11のHV放電コントローラ15は、この遅延時間ΔTの後に高電圧を下げるカスコード制御信号を特性線19の如く演算する。カスコード制御信号は、特性線19で示すように時間t4でゼロとなり、このときに、高電圧測定値(特性線20)は最小値となる。言い換えると、変圧器制御信号18がゼロになるのを条件に、HV放電コントローラ15内の高電圧指令値と測定値との偏差の大きさに応じて、所定のアルゴリズムで制御が開始される。結果として、所定の遅延時間の経過を待って、カスコードの制御は開始される。
ところで、カスコード回路を入れていなかった従来技術では、図4中に二点鎖線で示す特性線100の如く、高電圧を最小値にまで下げるのに時間t2~t5が必要となっている。即ち、従来技術のERダンパは、内部に封入した電気粘性流体が大きな時定数をもっているため、電気粘性流体に電界をかける電極に対して高電圧(HV)を印加した後に、この高電圧(HV)を電極から放電させる制御で、電荷が抜け難くなって余分な時間がかかり、減衰力制御の応答性が低下する原因となっている。
そこで、本実施の形態では、高電圧制御装置11を、高電圧指令値に基づいてERダンパ21の電極筒36に印加する高電圧(HV)の充電制御を行うため変圧器制御信号を出力するHV充電コントローラ13と、HV充電コントローラ13からの変圧器制御信号に従って電極筒36に印加する高電圧の変圧制御を行う変圧器14と、前記高電圧指令値に基づいて電極筒36に印加される高電圧の放電制御を行うためカスコード制御信号を出力するHV放電コントローラ15と、HV放電コントローラ15からのカスコード制御信号に従って電極筒36に印加された高電圧の放電制御を行うHVカスコード16と、により構成している。
このような構成とすることにより、高電圧制御装置11のHV放電コントローラ15からHVカスコード16にカスコード制御信号(図4中の特性線19)を出力して高電圧(HV)を電極筒36から放電させる制御を行うときに、電極筒36から前記高電圧(HV)の電荷が抜け易くなる。このため、高電圧モニタ12で検出される高電圧測定値は、図4中の特性線20の如く、時間t3~t4間で早期に最小値となり、時間t4の時点で電極筒36から電荷が抜ける。
従って、本実施の形態では、従来技術の特性線100による時間t5よりも早期に、時間t4で電極筒36から電荷を放電させる制御を完了することができ、減衰力制御の応答性を向上することができる。即ち、ERダンパ21の電極筒36に対する高電圧の印加と放電制御とを高い応答性をもって行ことができ、減衰力制御の信頼性、安定性を高めることができる。
また、高電圧制御装置11は、変圧器14とHVカスコード16とが同時に作動しないように、変圧器14とHVカスコード16とを並行(並列的)に制御する構成としている。これにより、変圧器14とHVカスコード16とが同時に動作することはなくなり、変圧器14からの高電圧(即ち、電気エネルギ)の供給と、HVカスコード16による放電制御(エネルギの消散)とを時間差をもって効率的に行うことができる。
なお、前記実施の形態では、サスペンション装置4のERダンパ21を縦置き状態で自動車等の車両に取付ける場合を例に挙げて説明した。しかし、本発明はこれに限らず、例えば、ERダンパ21を横置き状態で鉄道車両等の車両に取付ける構成としてもよい。即ち、ERダンパ21は、例えばエアレーションを起こさない範囲で傾けて配置する等、取付対象に応じて所望の方向に設置することができる。
以上説明した実施の形態に基づくサスペンション制御装置として、例えば、下記に述べる態様のものが考えられる。
第1の態様としては、サスペンション制御装置が提供される。このサスペンション制御装置は、車両の挙動を検出する車両挙動検出部と、前記車両の相対移動する2部材間に設けられた減衰力調整式緩衝器と、前記車両挙動検出部の検出結果に基づいて前記減衰力調整式緩衝器の減衰力を調整する制御装置と、を備える。前記減衰力調整式緩衝器は、電気粘性流体が封入されたシリンダと、該シリンダ内に摺動可能に挿入されたピストンと、該ピストンに連結されて前記シリンダの外部に延出するピストンロッドと、前記シリンダ内での前記ピストンの移動によって前記電気粘性流体の流れが生じる部分に設けられ、前記電気粘性流体に電界をかける電極と、を備える。前記制御装置は、前記車両挙動検出部の前記検出結果に基づいて前記減衰力を可変に調整するための高電圧指令値を求める指令制御装置と、前記指令制御装置から出力される前記高電圧指令値に基づいて前記電極に印加される高電圧をフィードバック制御する高電圧制御装置と、を備える。前記高電圧制御装置は、前記電極に印加される高電圧の充電制御を行うための変圧器制御信号を出力するHV充電コントローラと、前記電極に印加される前記高電圧の変圧制御を前記HV充電コントローラからの前記変圧器制御信号に従って行う変圧器と、前記電極に印加される前記高電圧の放電制御を行うためのカスコード制御信号を出力するHV放電コントローラと、前記電極に印加される前記高電圧の放電制御を前記HV放電コントローラからの前記カスコード制御信号に従って行うHVカスコードと、を備える。
第2の態様としては、前記第1の態様において、前記高電圧制御装置は、前記変圧器と前記HVカスコードとが同時に作動しないように、前記変圧器と前記HVカスコードとを並行的に制御する。第3の態様としては、前記第1または第2の態様において、前記HV充電コントローラはアナログコントローラであり、前記HV放電コントローラはデジタルコントローラである。第4の態様としては、前記第1の態様において、前記HV充電コントローラと前記HV放電コントローラとは、単一のコントローラとして一体的に形成される。
以上、本発明のいくつかの実施形態について説明してきたが、上述した発明の実施形態は、本発明の理解を容易にするためのものであり、本発明を限定するものではない。本発明は、その趣旨を逸脱することなく、変更、改良され得るとともに、本発明にはその均等物が含まれる。また、上述した課題の少なくとも一部を解決できる範囲、または、効果の少なくとも一部を奏する範囲において、特許請求の範囲および明細書に記載された各構成要素の任意の組み合わせ、または、省略が可能である。
本願は、2017年6月28日出願の日本特許出願番号2017-126101号に基づく優先権を主張する。2017年6月28日出願の日本特許出願番号2017-126101号の明細書、特許請求の範囲、図面及び要約書を含む全ての開示内容は、参照により全体として本願に組み込まれる。
1 車体(車両の相対移動する部材)、 2 車輪(車両の相対移動する部材)、 4 サスペンション装置、 6 ばね上加速度センサ(車両挙動検出部)、 7 ばね下加速度センサ(車両挙動検出部)、 8 制御装置、 9 指令制御装置、 11 高電圧制御装置、 13 HV充電コントローラ、 14 変圧器、 15 HV放電コントローラ、 16 HVカスコード、 21 ERダンパ(減衰力調整式緩衝器)、 22 ER流体(電気粘性流体)、 23 内筒(シリンダ)、 24 外筒(シリンダ)、 27 ピストン、 30 ピストンロッド、 36 電極筒(電極)
Claims (4)
- サスペンション制御装置であって、
車両の挙動を検出する車両挙動検出部と、
前記車両の相対移動する2部材間に設けられた減衰力調整式緩衝器と、
前記車両挙動検出部の検出結果に基づいて前記減衰力調整式緩衝器の減衰力を調整する制御装置と
を備え、
前記減衰力調整式緩衝器は、電気粘性流体が封入されたシリンダと、該シリンダ内に摺動可能に挿入されたピストンと、該ピストンに連結されて前記シリンダの外部に延出するピストンロッドと、前記シリンダ内での前記ピストンの移動によって前記電気粘性流体の流れが生じる部分に設けられ、前記電気粘性流体に電界をかける電極と、を備え、
前記制御装置は、
前記車両挙動検出部の前記検出結果に基づいて前記減衰力を可変に調整するための高電圧指令値を求める指令制御装置と、
前記指令制御装置から出力される前記高電圧指令値に基づいて前記電極に印加される高電圧をフィードバック制御する高電圧制御装置と
を備え、
前記高電圧制御装置は、
前記電極に印加される高電圧の充電制御を行うための変圧器制御信号を出力するHV充電コントローラと、
前記電極に印加される前記高電圧の変圧制御を前記HV充電コントローラからの前記変圧器制御信号に従って行う変圧器と、
前記電極に印加される前記高電圧の放電制御を行うためのカスコード制御信号を出力するHV放電コントローラと、
前記電極に印加される前記高電圧の放電制御を前記HV放電コントローラからの前記カスコード制御信号に従って行うHVカスコードと
を備える
サスペンション制御装置。 - 請求項1に記載のサスペンション制御装置であって、
前記高電圧制御装置は、前記変圧器と前記HVカスコードとが同時に作動しないように、前記変圧器と前記HVカスコードとを並行的に制御する
サスペンション制御装置。 - 請求項1または請求項2に記載のサスペンション制御装置であって、
前記HV充電コントローラはアナログコントローラであり、
前記HV放電コントローラはデジタルコントローラである
サスペンション制御装置。 - 請求項1に記載のサスペンション制御装置であって、
前記HV充電コントローラと前記HV放電コントローラとは、単一のコントローラとして一体的に形成された
サスペンション制御装置。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2017126101A JP2020142534A (ja) | 2017-06-28 | 2017-06-28 | サスペンション制御装置 |
| JP2017-126101 | 2017-06-28 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2019003907A1 true WO2019003907A1 (ja) | 2019-01-03 |
Family
ID=64741560
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2018/022508 Ceased WO2019003907A1 (ja) | 2017-06-28 | 2018-06-13 | サスペンション制御装置 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP2020142534A (ja) |
| WO (1) | WO2019003907A1 (ja) |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0891031A (ja) * | 1994-09-27 | 1996-04-09 | Nissan Motor Co Ltd | 車両用ショックアブソーバー |
| DE10110609A1 (de) * | 2001-03-06 | 2002-09-12 | Schenck Pegasus Gmbh | Hochspannungsnetzteil |
| WO2016171827A1 (en) * | 2015-04-23 | 2016-10-27 | Xilinx, Inc. | Circuits for and methods of implementing a charge/discharge switch in an integrated circuit |
| WO2017002620A1 (ja) * | 2015-06-30 | 2017-01-05 | 日立オートモティブシステムズ株式会社 | サスペンション制御装置 |
-
2017
- 2017-06-28 JP JP2017126101A patent/JP2020142534A/ja active Pending
-
2018
- 2018-06-13 WO PCT/JP2018/022508 patent/WO2019003907A1/ja not_active Ceased
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0891031A (ja) * | 1994-09-27 | 1996-04-09 | Nissan Motor Co Ltd | 車両用ショックアブソーバー |
| DE10110609A1 (de) * | 2001-03-06 | 2002-09-12 | Schenck Pegasus Gmbh | Hochspannungsnetzteil |
| WO2016171827A1 (en) * | 2015-04-23 | 2016-10-27 | Xilinx, Inc. | Circuits for and methods of implementing a charge/discharge switch in an integrated circuit |
| WO2017002620A1 (ja) * | 2015-06-30 | 2017-01-05 | 日立オートモティブシステムズ株式会社 | サスペンション制御装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP2020142534A (ja) | 2020-09-10 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111819092B (zh) | 悬架控制装置 | |
| JPWO2017002620A1 (ja) | サスペンション制御装置 | |
| JP2018052203A (ja) | サスペンション制御装置 | |
| CN106907422A (zh) | 电流变液减振器及其控制方法、控制单元、ecu及汽车 | |
| US11073190B2 (en) | Cylinder apparatus | |
| JP6586379B2 (ja) | 高電圧発生器および緩衝器 | |
| JP6745978B2 (ja) | シリンダ装置 | |
| WO2018021393A1 (ja) | サスペンション制御装置 | |
| JP6892378B2 (ja) | シリンダ装置 | |
| JP2020142534A (ja) | サスペンション制御装置 | |
| WO2019003994A1 (ja) | サスペンション制御装置 | |
| JP6986456B2 (ja) | シリンダ装置 | |
| JP6761897B2 (ja) | シリンダ装置 | |
| JP2019007600A (ja) | シリンダ装置 | |
| WO2019003893A1 (ja) | サスペンション制御装置 | |
| JP2020002980A (ja) | シリンダ装置 | |
| JP6975688B2 (ja) | シリンダ装置 | |
| JP6869837B2 (ja) | シリンダ装置 | |
| JP2019007601A (ja) | シリンダ装置 | |
| JP6838785B2 (ja) | サスペンション制御装置 | |
| JP2019007585A (ja) | シリンダ装置 | |
| JP2020143674A (ja) | シリンダ装置およびシリンダ装置の製造方法 | |
| JP2019007599A (ja) | シリンダ装置 | |
| JP2020051501A (ja) | サスペンション制御装置 | |
| JP2019007598A (ja) | サスペンション制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 18825335 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 18825335 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: JP |