JP2015104789A - ロボット - Google Patents
ロボット Download PDFInfo
- Publication number
- JP2015104789A JP2015104789A JP2013248935A JP2013248935A JP2015104789A JP 2015104789 A JP2015104789 A JP 2015104789A JP 2013248935 A JP2013248935 A JP 2013248935A JP 2013248935 A JP2013248935 A JP 2013248935A JP 2015104789 A JP2015104789 A JP 2015104789A
- Authority
- JP
- Japan
- Prior art keywords
- joint
- arm
- angular velocity
- robot
- sensor
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images





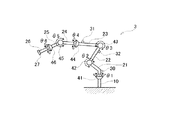

Landscapes
- Manipulator (AREA)
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2013248935A JP2015104789A (ja) | 2013-12-02 | 2013-12-02 | ロボット |
| CN201410718044.8A CN104669244A (zh) | 2013-12-02 | 2014-12-01 | 机器人 |
| US14/556,800 US9868209B2 (en) | 2013-12-02 | 2014-12-01 | Robot |
| US15/671,652 US9999974B2 (en) | 2013-12-02 | 2017-08-08 | Robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2013248935A JP2015104789A (ja) | 2013-12-02 | 2013-12-02 | ロボット |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2015104789A true JP2015104789A (ja) | 2015-06-08 |
| JP2015104789A5 JP2015104789A5 (enExample) | 2016-12-28 |
Family
ID=53435232
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2013248935A Pending JP2015104789A (ja) | 2013-12-02 | 2013-12-02 | ロボット |
Country Status (1)
| Country | Link |
|---|---|
| JP (1) | JP2015104789A (enExample) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2016175165A (ja) * | 2015-03-20 | 2016-10-06 | トヨタ自動車株式会社 | ジャイロセンサの配置方法 |
| US9950427B2 (en) | 2015-07-27 | 2018-04-24 | Seiko Epson Corporation | Robot, control apparatus, and robot system |
| JP2020011361A (ja) * | 2018-07-20 | 2020-01-23 | セイコーエプソン株式会社 | 制御装置、水平多関節ロボットおよびロボットシステム |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2010274396A (ja) * | 2009-06-01 | 2010-12-09 | Kawasaki Heavy Ind Ltd | 自動作業システムにおける位置ズレ補正方法及び位置ズレ補正プログラム |
| JP2011011318A (ja) * | 2009-07-06 | 2011-01-20 | Seiko Epson Corp | 位置制御方法、ロボット |
| JP2012232370A (ja) * | 2011-04-28 | 2012-11-29 | Seiko Epson Corp | ロボットコントローラー、簡易設置型ロボット、及び簡易設置型ロボットの制御方法 |
| JP2013099806A (ja) * | 2011-11-08 | 2013-05-23 | Seiko Epson Corp | ロボット及びロボットの制御方法 |
| JP2013146827A (ja) * | 2012-01-20 | 2013-08-01 | Seiko Epson Corp | ロボットの制御方法、ロボット |
-
2013
- 2013-12-02 JP JP2013248935A patent/JP2015104789A/ja active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2010274396A (ja) * | 2009-06-01 | 2010-12-09 | Kawasaki Heavy Ind Ltd | 自動作業システムにおける位置ズレ補正方法及び位置ズレ補正プログラム |
| JP2011011318A (ja) * | 2009-07-06 | 2011-01-20 | Seiko Epson Corp | 位置制御方法、ロボット |
| JP2012232370A (ja) * | 2011-04-28 | 2012-11-29 | Seiko Epson Corp | ロボットコントローラー、簡易設置型ロボット、及び簡易設置型ロボットの制御方法 |
| JP2013099806A (ja) * | 2011-11-08 | 2013-05-23 | Seiko Epson Corp | ロボット及びロボットの制御方法 |
| JP2013146827A (ja) * | 2012-01-20 | 2013-08-01 | Seiko Epson Corp | ロボットの制御方法、ロボット |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2016175165A (ja) * | 2015-03-20 | 2016-10-06 | トヨタ自動車株式会社 | ジャイロセンサの配置方法 |
| US9950427B2 (en) | 2015-07-27 | 2018-04-24 | Seiko Epson Corporation | Robot, control apparatus, and robot system |
| JP2020011361A (ja) * | 2018-07-20 | 2020-01-23 | セイコーエプソン株式会社 | 制御装置、水平多関節ロボットおよびロボットシステム |
| JP7183601B2 (ja) | 2018-07-20 | 2022-12-06 | セイコーエプソン株式会社 | ロボットシステムおよびロボットシステムの制御方法 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US9868209B2 (en) | Robot | |
| JP6111563B2 (ja) | ロボット | |
| JP5962340B2 (ja) | ロボット | |
| JP5652042B2 (ja) | ロボット装置、ロボット装置の制御方法およびプログラム | |
| JP6575200B2 (ja) | ロボット、制御装置およびロボットシステム | |
| US8972059B2 (en) | Displacement correcting method and displacement correcting program in automatic operation system | |
| JP7143633B2 (ja) | ロボットシステム、制御装置および制御方法 | |
| CN107379016A (zh) | 可动部的振动测定方法、机器人的振动测定方法以及控制装置 | |
| JP5417161B2 (ja) | ロボットの制振方法およびロボットの制御装置 | |
| JP5891718B2 (ja) | ロボット | |
| JP6248544B2 (ja) | ロボット、制御装置、ロボットシステム | |
| CN104736303B (zh) | 多关节机器人的摆动控制装置 | |
| JP2016013613A (ja) | ロボット制御方法、ロボット装置、プログラム、記録媒体及び組立部品の製造方法 | |
| JP2008307634A (ja) | 嵌合装置 | |
| JP5277946B2 (ja) | ロボット制御装置およびロボットシステム | |
| JP2017148913A (ja) | ロボット、制御装置及びロボットの制御方法 | |
| CN109015628B (zh) | 控制装置、机器人以及机器人系统 | |
| JP6252272B2 (ja) | 垂直多関節型ロボットの位置誤差抑制方法 | |
| JP2020131388A (ja) | ロボットシステム、制御装置、および制御方法 | |
| CN112584989B (zh) | 机器人系统和机器人系统的控制方法 | |
| JP6036476B2 (ja) | ロボット | |
| JP2017056558A (ja) | ロボット | |
| JP2024071866A (ja) | ロボットの制御方法およびロボットシステム | |
| JP2011058820A (ja) | 角速度センサーの補正方法 | |
| JP2015150630A (ja) | ロボット |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| RD04 | Notification of resignation of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7424 Effective date: 20160617 |
|
| RD03 | Notification of appointment of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7423 Effective date: 20160627 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20161109 |
|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20161109 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20170905 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20171018 |
|
| A02 | Decision of refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A02 Effective date: 20171205 |