Novel 3D massage core and massage armchair
Technical Field
The invention relates to the technical field of massage chairs, in particular to a novel 3D massage machine core and a massage chair.
Background
The existing massage chair comprises a massage chair framework and a massage machine core, and the principle of the conventional massage chair is to utilize mechanical rolling force action and mechanical force extrusion to massage. The massage machine core of the massage chair simulates the kneading manipulation of a masseur, applies massage such as traction, extrusion, kneading and the like to the sore and numb muscles on the back, generates soft stimulation to the muscles, and performs kneading massage with different forces on the gravity points, thereby recovering the elasticity of muscle fibers and accelerating the blood circulation speed.
The 3D massage function is a major breakthrough of the current massage chair, a guide rail is arranged on a massage chair framework, a massage mechanism comprises a mounting frame, the mounting frame can slide up and down along the guide rail, a massage wheel component for massaging the human body, a kneading component for driving the massage component to knead and a knocking component for driving the massage component to knock are arranged on the mounting frame, a walking component for driving the mounting frame to move along the guide rail is arranged between the mounting frame and the guide rail, the walking component comprises a driving walking shaft, walking rollers, a walking gear and a walking motor, the driving walking shaft is rotationally arranged on the mounting frame, the walking motor is fixedly arranged on the mounting frame and drives the driving walking shaft to rotate, the walking rollers are arranged at the end part of the driving walking shaft and can roll along the guide rail, the walking gear is arranged beside the walking rollers, a rack meshed with the walking gear is arranged on the guide rail, and the, thereby driving the mounting rack to slide up and down along the guide rail. However, the massage wheel component, the kneading component and the knocking component on the massage mechanism are all arranged on the kneading knocking frame, the kneading knocking frame is fixedly arranged on the mounting frame, and the massage wheel component cannot be driven to move towards the direction close to or far away from the human body due to the fixed arrangement of the kneading knocking frame, so that the position of the massage wheel component cannot be adjusted as required, and the massage wheel component is not attached to the human body. And the actions of kneading, knocking and jacking are often carried out in a linkage manner, so that the required massage scheme is inconvenient to adjust according to actual needs, and the requirements of consumers cannot be met.
Disclosure of Invention
In order to overcome the defects, the invention aims to provide a novel 3D massage machine core which is compact in structure, more fit with a human body and convenient for realizing the respective walking, kneading, knocking and jacking.
In order to achieve the above purposes, the invention adopts the technical scheme that: the utility model provides a novel 3D massage core, can follow walking rail mounted, its characterized in that: the device comprises a bottom plate, wherein a travelling mechanism, a jacking mechanism and a kneading mechanism positioned between the travelling mechanism and the jacking mechanism are arranged on the bottom plate, the travelling mechanism comprises a travelling shaft which can rotate along the bottom plate under the action of a travelling driving piece, and travelling wheels which can travel along a travelling track are rotatably connected at two ends of the travelling shaft; the jacking mechanism comprises a rotating shaft arranged in parallel with the travelling shaft, the rotating shaft rotates along the bottom plate under the action of a jacking driving piece, jacking travelling wheels capable of travelling along the travelling rail are eccentrically arranged at two ends of the rotating shaft, and the jacking travelling wheels drive the bottom plate to swing by taking the travelling shaft as an axis in the rotating process of the rotating shaft; the kneading mechanism comprises a kneading shaft and a knocking shaft, the kneading shaft and the knocking shaft rotate under the action of a kneading driving piece and a knocking driving piece respectively, two kneading arm groups capable of performing reciprocating left and right kneading when the kneading shaft rotates are sleeved on the kneading shaft, a knocking group corresponding to the kneading arm groups is sleeved on the knocking shaft, and the knocking group pushes the kneading arm groups to perform reciprocating front and back knocking when the knocking shaft rotates.
The invention has the beneficial effects that: when the walking driving piece of the walking mechanism drives the walking shaft to rotate, the whole bottom plate can be driven to walk along the walking track. When the jacking driving piece drives the rotating shaft to rotate, the jacking travelling wheel abutted against the walking track is eccentrically arranged with the rotating shaft, so that the whole bottom plate can be pushed to swing by taking the walking shaft as an axis when the jacking travelling wheel walks along the walking track, and the front and back reciprocating jacking of the kneading arm assembly on a human body is realized. When the kneading driving piece drives the kneading shaft to rotate, the kneading arm group carries out reciprocating left and right kneading. When the knocking driving piece drives the knocking circular rotation, the knocking group pushes the kneading arm group to perform reciprocating back and forth hammering. The whole machine core has compact structure, and the actions of walking, kneading, knocking and jacking can be independently controlled and realized.
Further, the walking driving part, the jacking driving part, the kneading driving part and the knocking driving part are all brushless motors fixed on the bottom plate. The output shaft of the brushless motor is fixedly connected with a turbine rod, the walking shaft, the rotating shaft, the kneading shaft and the knocking shaft are respectively and fixedly provided with a helical gear meshed with the corresponding turbine rod, and the walking shaft, the rotating shaft, the kneading shaft and the knocking shaft can rotate through the linkage of the turbine rod and the helical gear. The brushless motor saves space, and has small noise and large torque.
Furthermore, connecting blocks are fixed at two ends of the rotating shaft, a fixed shaft which is eccentrically arranged with the rotating shaft is arranged on each connecting block, and the jacking travelling wheel is rotatably connected with the fixed shaft. The eccentric connection of the jacking travelling wheel and the rotating shaft is realized through the connecting block which is eccentrically arranged.
Further, the kneading arm group comprises an eccentric wheel which is sleeved on the kneading shaft and synchronously rotates with the kneading shaft, a connecting seat is fixed on the eccentric wheel, a massaging arm is hinged on the connecting seat, the end part of the massaging arm is rotatably connected with a massaging head, and a spring is arranged between the massaging arm and the connecting seat. The eccentric wheels are symmetrically arranged, and when the kneading shaft rotates, the two kneading arms move close to or away from each other in a reciprocating manner, so that kneading is realized. The massage arm is hinged with the connecting seat, the position can be adjusted within a certain range according to the position, and the spring can realize quick reset.
Further, be provided with on the connecting seat and supply massage arm pivoted recess, the radian of recess has injectd the control range of massage arm, is provided with the dead lever that supplies the spring both ends to fix respectively on massage arm and the connecting seat, and the spring is the extension spring.
The knocking shaft comprises a driving section, a first eccentric section and a second eccentric section, wherein the first eccentric section and the second eccentric section are positioned at two ends of the driving section, the bottom plate is provided with a first bearing seat, two ends of the driving section penetrate through the bearing seats to form the first eccentric section and the second eccentric section, a helical gear capable of being meshed with an output shaft of the knocking driving piece is fixed on the driving section, the first eccentric section and the second eccentric section are eccentrically arranged with the driving section, axes of the first eccentric section, the second eccentric section and the driving section are parallel to each other, and the knocking group is respectively sleeved on the first eccentric section and the second eccentric section. When the knocking shaft rotates, the two knocking groups can alternately move back and forth to push the kneading arm group.
Further, the knocking group comprises a knocking seat which is fixed on the first eccentric section or the second eccentric section and synchronously rotates with the first eccentric section or the second eccentric section, a ball head connecting rod capable of swinging left and right along the knocking seat is hinged to the knocking seat, and a ball groove matched with the ball head connecting rod is formed in the kneading arm group.
Further, a walking groove for embedding and walking of a walking wheel and a jacking travelling wheel is formed in the walking track, the walking wheel and the jacking travelling wheel are the same in size, a rack is further arranged on the walking track, and a walking gear meshed with the rack is fixed on the walking shaft.
The invention also provides a massage chair which is compact in structure, more fit with a human body and convenient for realizing the respective walking, kneading, knocking and jacking.
In order to achieve the above purposes, the invention adopts the technical scheme that: a massage chair is characterized by comprising the novel 3D massage machine core. The electric shoe is more fit for a human body, has compact structure and low noise, and is convenient for realizing respective walking, kneading, knocking and jacking.
The walking track becomes the curved structure of laminating human back, including the back portion that supplies the seat to stand and supply the back to rely on, when whole core walked to sitting the standing under the running gear effect, knead arm group shrink and do not move, knead arm group and back contact not to arrive, do not have the body and feel, the massage armchair can hold the seat sense and the comfort as the sofa this moment. When the whole machine core moves to the back under the action of the walking mechanism, the softness of massage can be changed and the force to the back can be reduced by controlling the top pressing driving piece, the knocking driving piece and the kneading driving piece independently or jointly according to different parts of the back.
Drawings
FIG. 1 is a schematic structural diagram of an embodiment of the present invention;
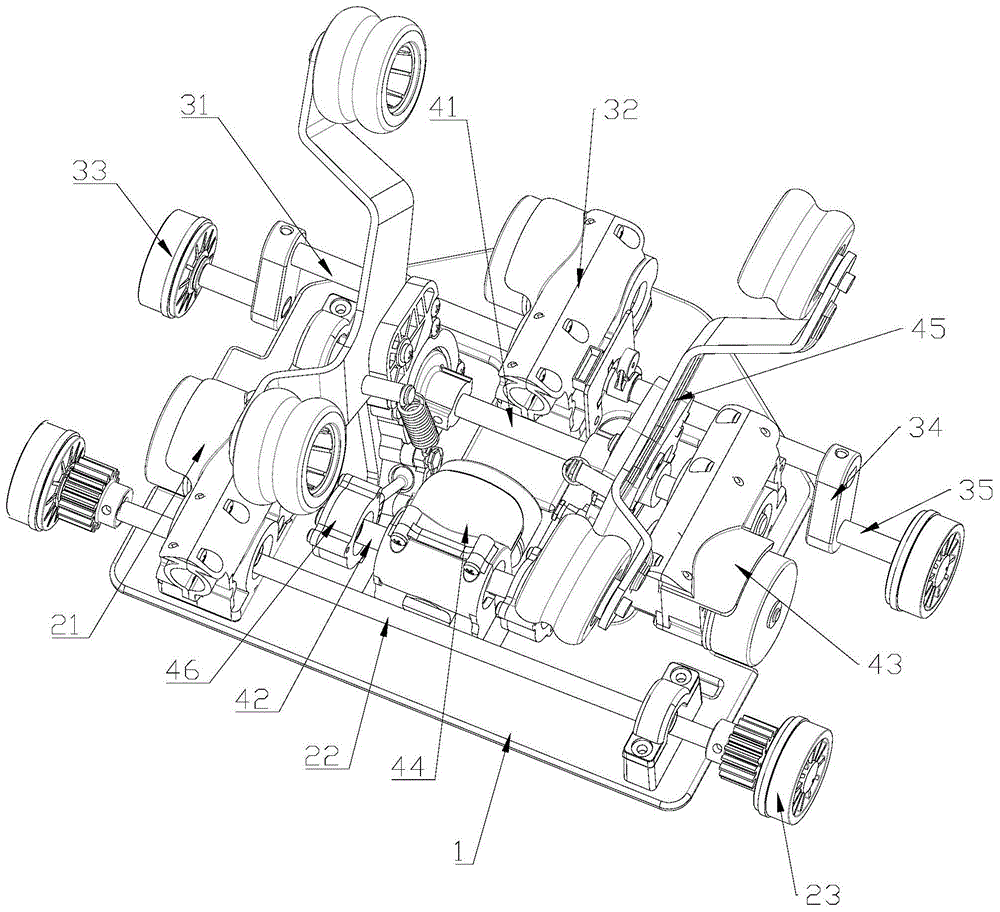
fig. 2 is a perspective view of a massage movement in an embodiment of the present invention;
FIG. 3 is a schematic structural diagram of a traveling mechanism and a constant pressure mechanism in an embodiment of the invention;
FIG. 4 is a perspective view of the kneading mechanism in the embodiment of the present invention;
FIG. 5 is a top view of the kneading mechanism in an embodiment of the present invention;
FIG. 6 is a schematic view of a linkage structure of a kneading shaft and a kneading driving member according to an embodiment of the present invention;
fig. 7 is a schematic structural diagram of a knocking shaft in an embodiment of the present invention.
In the figure:
100-running rail, 1 a-running groove, 1 b-rack, 1-base plate, 2-running mechanism, 21-running drive, 22-running shaft, 221-running gear, 23-running wheel, 3-pressing mechanism, 31-rotating shaft, 32-pressing drive, 33-pressing wheel, 34-connecting block, 35-fixed shaft, 4-kneading mechanism, 41-kneading shaft, 42-knocking shaft, 421-driving section, 422-first eccentric section, 423-second eccentric section, 43-kneading drive, 44-knocking drive, 45-kneading arm set, 451-eccentric wheel, 452-connecting seat, 453-massaging arm, 454-massaging head, 455-spring, 46-knocking set, 461-knocking seat and 462-ball connecting rod.
Detailed Description
The following detailed description of the preferred embodiments of the present invention, taken in conjunction with the accompanying drawings, will make the advantages and features of the invention easier to understand by those skilled in the art, and thus will clearly and clearly define the scope of the invention.
Examples
Referring to fig. 1-7, the novel 3D massage machine core of the present invention, which can travel along a travel track 100, includes a bottom plate 1, wherein the bottom plate 1 is provided with a traveling mechanism 2, a pressing mechanism 3 and a kneading mechanism 4, and the kneading mechanism 4 is located between the traveling mechanism 2 and the pressing mechanism 3.
The running mechanism 2 can drive the whole movement to move along the running track 100. The traveling mechanism 2 includes a traveling shaft 22 capable of rotating along the base plate 1 under the action of the traveling drive member 21, and traveling wheels 23 capable of traveling along the traveling rail 100 are rotatably connected to both ends of the traveling shaft 22. Two bearing seats are arranged on the bottom plate 1, and two ends of the walking shaft 22 penetrate through the bearing seats to be connected with the walking wheels 23. The walking driving part 21 is a brushless motor and is fixed on the bottom plate 1, a worm is fixedly connected with an output shaft of the brushless motor, a helical gear meshed with the worm is fixed on the walking shaft 22, when the brushless motor works, the walking shaft 22 rotates through the worm and the helical gear, and the helical gear is arranged at one end, penetrating out of a bearing seat, of the walking shaft 22, so that the space is saved.
The jacking mechanism 3 is used for driving the whole movement to jack the back front and back, the jacking mechanism 3 comprises a rotating shaft 31 arranged in parallel with the walking shaft 22, and the rotating shaft 31 rotates along the bottom plate 1 under the action of a jacking driving piece 32. The base plate 1 is provided with a bearing seat, and two ends of the rotating shaft 31 penetrate through the bearing seat. The jacking driving part 32 is a brushless motor and is fixed on the bottom plate 1, a worm rod is fixedly connected with an output shaft of the brushless motor, a helical gear meshed with the worm is fixed on the rotating shaft 31, the rotation of the rotating shaft 31 is realized through the worm and the helical gear when the brushless motor works, the helical gear is arranged at the central position of the rotating shaft 31, and the stability is good.
Two ends of the rotating shaft 31 are eccentrically provided with a jacking traveling wheel 33 capable of traveling along the traveling rail 100, and the jacking traveling wheel 33 drives the bottom plate 1 to swing around the traveling shaft 22 as an axis in the traveling process. Connecting blocks 34 are fixed at two ends of the rotating shaft 31, a fixed shaft 35 eccentrically arranged with the rotating shaft 31 is arranged on each connecting block 34, and the jacking travelling wheel 33 is rotatably connected with the fixed shaft 35. The eccentric connection between the jacking travelling wheel 33 and the rotating shaft 31 is realized through the connecting block 34 which is arranged eccentrically.
The walking track 100 is provided with a walking groove 1a for the walking wheels 23 and the jacking travelling wheels 33 to be embedded and walk, and the walking wheels 23 and the jacking travelling wheels 33 have the same size and are matched with the walking groove 1 a. The running rail 100 is further provided with a rack 1b, and a running gear 221 engaged with the rack 1b is fixed to the running shaft 22.
The kneading mechanism 4 is used for kneading and beating the back, and the kneading and beating can be carried out synchronously or respectively according to the requirement. The kneading mechanism 4 includes a kneading shaft 41 and a knocking shaft 42, the kneading shaft 41 and the knocking shaft 42 are disposed between the traveling shaft 22 and the main shaft and are disposed in parallel with the main shaft, the kneading shaft 41 is disposed on a side close to the traveling shaft 22, and the knocking shaft 42 is disposed on a side close to the main shaft. Knead axle 41 and strike axle 42 and rotate under kneading driving piece 43 and knocking driving piece 44 effect respectively, knead driving piece 43 and strike driving piece 44 and be brushless motor and fix on bottom plate 1, be provided with the bearing frame on the bottom plate 1, knead axle 41 and bearing frame rotation connection, knead driving piece 43's output shaft and consolidate and have the worm, knead the one end of axle 41 and run through the bearing frame and consolidate and have the helical gear with worm meshing. Two kneading arm groups 45 capable of performing reciprocating left and right kneading when the kneading shaft 41 rotates are sleeved on the kneading shaft 41, a knocking group 46 corresponding to the kneading arm groups 45 is sleeved on the knocking shaft 42, and the knocking group 46 pushes the kneading arm groups 45 to perform reciprocating front and back knocking when the knocking shaft 42 rotates.
The brushless motor saves space, and has small noise and large torque.
The kneading arm set 45 comprises an eccentric wheel 451 which is sleeved on the kneading shaft 41 and rotates synchronously with the kneading shaft 41, a connecting seat 452 is fixed on the eccentric wheel 451, a massage arm 453 is hinged on the connecting seat 452, a massage head 454 is rotatably connected at the end of the massage arm 453, and a spring 455 is arranged between the massage arm 453 and the connecting seat 452. The eccentric wheels 451 are symmetrically arranged, and when the kneading shaft 41 rotates, the two kneading arms move back and forth to realize kneading. The massage arm 453 is hinged to the connecting base 452, and the position of the massage arm 455 can be adjusted within a certain range according to the position of the massage arm, so that the massage arm can be quickly reset. The connecting seat 452 is provided with a groove for the rotation of the massage arm 453, the radian of the groove limits the adjusting range of the massage arm 453, the massage arm 453 and the connecting seat 452 are respectively provided with a fixing rod for fixing two ends of the spring 455, and the spring 455 is a tension spring.
The knocking shaft 42 includes a driving section 421, and a first eccentric section 422 and a second eccentric section 423 located at two ends of the driving section 421, a first bearing seat is provided on the bottom plate 1, and a first eccentric section 422 and a second eccentric section 423 are provided at two ends of the driving section 421 through the bearing seat. The driving section 421 is fixed with a helical gear capable of meshing with an output shaft of the knocking driving member 44, the helical gear is located at the center of the driving section 421, the first eccentric section 422 and the second eccentric section 423 are eccentrically arranged with the driving section 421, the axes of the first eccentric section 422 and the second eccentric section 423 are parallel to the driving section 421, the eccentric directions of the first eccentric section 422 and the second eccentric section 423 are different, and the knocking group 46 is respectively sleeved on the first eccentric section 422 and the second eccentric section 423. The tapping shaft 42, when rotated, causes the two tapping sets 46 to move alternately back and forth to push the kneading arm set 45.
The knocking group 46 comprises a knocking seat 461 fixed on the first eccentric section 422 or the second eccentric section 423 and synchronously rotating with the first eccentric section 422 or the second eccentric section 423, a ball head connecting rod 462 capable of swinging left and right is hinged on the knocking seat 461, and a ball groove matched with the ball head connecting rod 462 is arranged on the kneading arm group 45 and is arranged on the connecting seat 452.
When the traveling shaft 22 is rotated by the traveling drive member 21 of the traveling mechanism 2, the entire base plate 1 can be driven to travel along the traveling rail 100. When the top pressure driving part 32 drives the rotating shaft 31 to rotate, the top pressure traveling wheel 33 abutted against the traveling rail 100 is eccentrically arranged with the rotating shaft 31, so that the whole bottom plate 1 can be pushed to swing by taking the traveling shaft 22 as an axis while the top pressure traveling wheel 33 travels along the traveling rail 100, and the front and back reciprocating top pressure of the kneading arm group 45 on a human body is realized. When the kneading shaft 41 is rotated by the kneading drive unit 43, the kneading arm group 45 performs reciprocating left and right kneading. When the knocking drive member 44 drives the knocking rotation, the knocking group 46 pushes the kneading arm group 45 to perform reciprocating back and forth hammering. The whole machine core has compact structure, and the actions of walking, kneading, knocking and jacking can be independently controlled and realized.
Example 2
The invention further provides a massage chair which comprises the novel 3D massage machine core in the embodiment 1, so that the massage chair is compact in structure, is more fit with a human body, and is convenient to walk, knead, knock and press respectively.
The walking track is a curved structure which is attached to the back of a human body and comprises a sitting part for the human body to sit on and a back part for the back to lean on, when the whole movement moves to the sitting part under the action of the walking mechanism 2, the kneading arm set 45 contracts and does not move, the kneading arm set 45 does not contact with the back, no body feeling exists, and the massage chair can bear the sitting feeling and the comfortable feeling of the sofa at the moment. When the whole machine core moves to the back under the action of the moving mechanism 2, the softness of massage can be changed and the force to the back can be reduced by controlling the jacking driving piece 32, the knocking driving piece 44 and the kneading driving piece 43 independently or jointly according to different parts of the back.
The above embodiments are merely illustrative of the technical concept and features of the present invention, and the present invention is not limited thereto, and any equivalent changes or modifications made according to the spirit of the present invention should be included in the scope of the present invention.