WO2024009583A1 - 車両制御装置 - Google Patents
車両制御装置 Download PDFInfo
- Publication number
- WO2024009583A1 WO2024009583A1 PCT/JP2023/015160 JP2023015160W WO2024009583A1 WO 2024009583 A1 WO2024009583 A1 WO 2024009583A1 JP 2023015160 W JP2023015160 W JP 2023015160W WO 2024009583 A1 WO2024009583 A1 WO 2024009583A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- vehicle
- similarity
- information
- interruption
- control device
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W50/08—Interaction between the driver and the control system
- B60W50/14—Means for informing the driver, warning the driver or prompting a driver intervention
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
Definitions
- the present disclosure relates to a vehicle control device.
- the vehicle control system described in Patent Document 1 below includes a recognition section, a specification section, and a travel control section (paragraph 0006, claim 1, summary, and FIG. 1).
- the recognition unit recognizes one or more surrounding vehicles existing in a second lane different from the first lane in which the own vehicle exists.
- the identification unit derives an index value based on the probability of cutting in front of the own vehicle for the surrounding vehicle recognized by the recognition unit, and identifies a surrounding vehicle for which the derived index value is equal to or higher than a threshold value as the cutting vehicle. .
- the travel control section decelerates the host vehicle depending on the presence of the cutting vehicle specified by the identification section. When decelerating the host vehicle, this travel control unit determines the degree of change in the deceleration of the host vehicle based on the index value of the target cutting vehicle.
- a nearby vehicle whose index value based on the probability of cutting in ahead of the own vehicle is equal to or greater than a threshold value is identified as the cutting vehicle. Then, when decelerating the host vehicle in response to the presence of the cut-in vehicle, the degree of change in the deceleration of the host vehicle is determined based on the index value of the target cut-in vehicle. Thereby, appropriate speed control can be performed in response to interruptions from surrounding vehicles (Patent Document 1, paragraph 0015).
- the vehicle's occupants are usually given an audio or visual warning or a warning via the vehicle's user interface. Notification will be given. Therefore, in situations where interruptions occur frequently, such as during traffic jams, warnings and notifications are issued frequently, which may distract the vehicle's occupants and reduce safety. .
- the present disclosure provides a vehicle control device that can suppress a decrease in occupant attention due to excessive warnings and notifications.
- One aspect of the present disclosure is a vehicle control device that controls the operation of a vehicle, which includes: an object detection unit that detects an object based on an output of an external sensor mounted on the vehicle; an interruption detection unit that detects an interruption of an object; a storage unit that records interruption information including a trajectory of the object where the interruption was detected; and history information of the interruption information recorded in the storage unit. and a similarity calculation unit that calculates a degree of similarity between the information and the most recent interruption information detected by the interruption detection unit, and an operation determination unit that determines an operation of the vehicle according to the degree of similarity.
- This is a vehicle control device characterized by:
- FIG. 1 is a block diagram showing an embodiment of a vehicle control device according to the present disclosure.
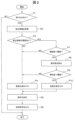
- FIG. 2 is a flow diagram illustrating the operation of the vehicle control device shown in FIG. 1.
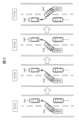
- FIG. FIG. 2 is a plan view illustrating an object cutting into the path of the vehicle shown in FIG. 1;
- FIG. 1 is a block diagram showing an embodiment of a vehicle control device according to the present disclosure.
- the vehicle control device 15 of this embodiment is, for example, an electronic control unit (ECU) that is mounted on the vehicle 1 and controls the operation of each part of the vehicle 1.
- the vehicle 1 includes, for example, an external sensor 11, a vehicle sensor 12, an actuator 13, a user interface 14, and a vehicle control device 15.
- the external sensor 11 includes, for example, an imaging device.
- the imaging device includes, for example, at least one of a monocular camera and a stereo camera.
- the external sensor 11 can include, for example, at least one of LiDAR (laser radar), millimeter wave radar, ultrasonic sensor, or infrared sensor.
- LiDAR laser radar
- the external sensor 11 detects objects around the vehicle 1, for example, and outputs the detection results to the vehicle control device 15 as external sensor information.
- the vehicle sensors 12 include, for example, a position sensor, a speed sensor, an acceleration sensor, a yaw rate sensor, an engine rotation sensor, a steering angle sensor, a gear position sensor, a pedal stroke sensor, and the like.
- the position sensor includes, for example, a Global Navigation Satellite System (GNSS) receiver.
- the speed sensor includes, for example, a wheel speed sensor.
- the vehicle sensor 12 detects vehicle information including, for example, the position, speed, acceleration, etc. of the vehicle 1, and outputs the detection result to the vehicle control device 15 as vehicle sensor information.
- GNSS Global Navigation Satellite System
- the actuator 13 includes various actuators that operate various parts of the vehicle 1, such as opening and closing a throttle valve, operating a brake, operating a transmission, or operating a steering wheel.
- the actuator 13 operates each part of the vehicle 1 based on a control signal input from the vehicle control device 15, for example.
- the user interface 14 includes, for example, an audio output device and a display device.
- the audio output device includes, for example, a speaker and a buzzer.
- the display device includes, for example, at least one of a head-up display, a liquid crystal display, an organic EL display, an instrument panel, or a display lamp.
- the user interface 14 may also include, for example, a vibration motor built into the seat or steering wheel.
- the vehicle control device 15 includes, for example, one or more microcontrollers (MCU), a central processing unit (CPU), memories such as RAM and ROM, a timer, an input/output unit, and the like. Further, the vehicle control device 15 may include a storage device such as a hard disk, for example. Vehicle control device 15 controls each part of vehicle 1 including at least one of actuator 13 and user interface 14 of vehicle 1, based on the output of at least one of external world sensor 11 and vehicle sensor 12, for example.
- the vehicle control device 15 includes a sensor information acquisition section 151, an object detection section 152, an interruption detection section 153, a storage section 154, a similarity calculation section 155, and an operation determination section 151. section 156 and a control signal generation section 157.
- Each of these parts of the vehicle control device 15 represents each function of the vehicle control device 15 that is realized by, for example, executing a program stored in the memory or storage device of the vehicle control device 15 by the CPU.
- each part of the vehicle control device 15 may include, for example, one or more portions formed by a single device, or one portion may be formed from a plurality of devices.
- FIG. 2 is a flow diagram illustrating the operation of the vehicle control device 15 shown in FIG.
- FIG. 3 is a plan view illustrating an object cutting into the path of the vehicle 1 shown in FIG.
- the vehicle control device 15 When the vehicle control device 15 starts the process flow shown in FIG. 2, it first executes a process P1 to determine whether or not an object interrupts the course of the vehicle 1.
- the target object includes, for example, a moving object such as a vehicle such as a passenger car, bus, or truck, a motorcycle, a bicycle, a cart, a pedestrian, or an animal that enters the path of the vehicle 1, which is the host vehicle.
- the sensor information acquisition unit 151 of the vehicle control device 15 acquires external world sensor information, which is the output of the external world sensor 11 mounted on the vehicle 1, for example. More specifically, the sensor information acquisition unit 151 acquires an image as external world sensor information from, for example, a monocular camera or a stereo camera included in the external world sensor 11, and adjusts the image characteristics for further processing.
- This image characteristic adjustment process includes, for example, an image resolution adjustment process that downscales or upscales the image and changes the resulting image size, and an image region of interest selection process that performs cropping that cuts out a predetermined area of the input image. Including.
- the parameters used in these processes can be changed as appropriate depending on, for example, the driving environment, speed, turning speed, etc. of the vehicle 1.
- the sensor information acquisition unit 151 outputs, for example, external sensor information including a processed image subjected to these processes to the target object detection unit 152.
- the sensor information acquisition unit 151 acquires vehicle sensor information that is the output of the vehicle sensor 12, for example.
- the sensor information acquisition section 151 outputs sensor information including the outside world sensor information and the vehicle sensor information acquired from the outside world sensor 11 and the vehicle sensor 12 to the object detection section 152 and the operation determination section 156, for example.
- the target object detection section 152 detects the target object based on the external sensor information input from the sensor information acquisition section 151. More specifically, the object detection unit 152 uses, for example, a pre-trained classifier to detect objects including vehicles using processed images included in the external sensor information input from the sensor information acquisition unit 151. Detection is performed. Classifiers include, for example, convolutional neural networks, pattern matching, decision trees, and the like.
- the object detection unit 152 outputs objects classified as vehicles, such as cars, trucks, buses, and motorcycles, to the interruption detection unit 153, along with feature amounts related to the objects.
- the feature amount related to the object includes, for example, the position and speed of the object, but can also include the trajectory of the object, the type of the object, and the like.
- detecting an object means, for example, processing that calculates at least the position of the object, the type of the object, the distance from the vehicle 1 to the object in three-dimensional space, and the speed of the object. do.
- the object detection unit 152 outputs information about objects around the vehicle 1 detected based on the output of the external sensor 11 to the motion determination unit 156, for example.
- the interruption detection unit 153 detects that the lateral speed included in the feature amount of the cutting vehicle Vc1 inputted from the target object detection unit 152 is a predetermined value for a predetermined period of time in a predetermined section of the course of the vehicle 1. If the threshold value is exceeded, it is determined that the cutting vehicle Vc1 has cut in.
- the interruption information of the object recorded in the storage unit 154 may include information other than the trajectory of the object, such as the position, speed, moving direction, and type of the object.
- the storage unit 154 deletes the interrupt information recorded in the memory or storage device after a predetermined period has elapsed.
- the predetermined period for deleting the interrupt information is set, for example, based on the expiration date of the time stamp, which varies depending on the driving conditions of the vehicle 1.
- the vehicle control device 15 executes a process P3 to determine whether there is a history of interrupt information.
- the operation determining unit 156 determines the operation of each part of the vehicle including the actuator 13 and the user interface 14 based on the high priority given to the most recent interrupt information.
- the operation determining unit 156 determines, for example, an operation that causes the audio output device of the user interface 14 to generate a first warning sound with a normal sound pressure. Further, the operation determining unit 156 determines an operation for displaying a warning on the display device of the user interface 14, for example. Further, the operation determining unit 156 may determine, for example, an operation of the actuator 13 that decelerates the vehicle 1, or an operation that vibrates a vibration motor built into the seat or steering wheel. The motion determining section 156 outputs the determined motion to the control signal generating section 157.
- control signal generation unit 157 executes a process P6 in which a control signal is generated based on the operation input from the operation determination unit 156 and outputted to each part of the vehicle 1. More specifically, the control signal generation unit 157 generates, for example, a control signal that causes the audio output device of the user interface 14 to generate a first warning sound with a normal sound pressure, and transmits the control signal to the audio output device of the user interface 14. Output.
- control signal generation unit 157 generates a control signal for displaying a warning on the display device of the user interface 14, and outputs it to the display device of the user interface 14, for example. Further, the control signal generation unit 157 generates, for example, a control signal that causes the actuator 13 to perform an operation of decelerating the vehicle 1, and outputs the control signal to the actuator 13. Further, the control signal generation unit 157 generates a control signal for vibrating a vibration motor built into a seat or a steering wheel, and outputs the control signal to the vibration motor.
- a warning will be displayed on the display device.
- the actuator 13 of the vehicle 1 operates to decelerate the vehicle 1, and vibration motors built into the steering wheel or the seat vibrate.
- the vehicle control device 15 calls the attention of the occupants of the vehicle 1 by issuing a normal warning or notification for an interrupt that is not similar to the history information of past interrupt information.
- the interruption detection unit 153 determines that there is an interruption (YES), and in processing P2, the interruption information of the interrupting vehicle Vc2 is stored in the storage unit 154. recorded.
- the similarity calculation unit 155 outputs the set similarity to the action determination unit 156.
- a first warning sound of normal sound pressure is emitted from the audio output device.
- a warning is displayed on the display device of the user interface 14, the actuator 13 of the vehicle 1 operates to decelerate the vehicle 1, and the vibration motors built into the seat and steering wheel vibrate.
- the vehicle control device 15 issues a normal warning or notification regarding the interruption of the most recent object to alert the occupants of the vehicle 1. evoke
- the processing flow shown in FIG. 2 ends and starts again.
- the interruption detection unit 153 determines that there is an interruption (YES), and in process P2, the interruption information of the interrupting vehicle Vc3 is recorded in the storage unit 154.
- a process P7 is executed to determine whether the number of pieces of history information is greater than a threshold value.
- the similarity calculation unit 155 executes a process P8 for calculating the similarity between the history information of past interrupt information recorded in the storage unit 154 and the latest interruption information detected by the interruption detection unit 153. do.
- the similarity calculation unit 155 calculates the following equation based on the Euclidean distance between the trajectory included in the latest interruption information and the trajectory included in the history information of past interruption information. Calculate the loss of similarity using (1).
- the weight in equation (1) above is assigned to each piece of historical information of past interrupt information, and for example, the weight becomes larger as the time elapsed from the interrupt occurrence time is shorter, and becomes smaller as the elapsed time from the interrupt occurrence time becomes longer.
- the comparison result of the above equation (1) is, for example, 0 if the Euclidean distance between the most recent interrupt information trajectory and the past interrupt information trajectory is smaller than the threshold, and 1 if it is greater than or equal to the threshold. becomes.
- the similarity calculation unit 155 calculates a loss in similarity with respect to history information of all past interrupt information.
- the similarity calculation unit 155 calculates that the loss of similarity between the most recent interruption information and the past interruption information is higher than that of the most recent interruption information. Assign similarity. Further, the similarity calculation unit 155 calculates, for example, that when the loss of similarity between the latest interruption information and the past interruption information is equal to or greater than a predetermined similarity constant, Assign similarity. The similarity calculation unit 155 outputs the similarity assigned to the latest interrupt information to the operation determination unit 156.
- the operation determining unit 156 executes a process P9 to determine whether the degree of similarity between the most recent interrupt information inputted from the similarity calculating unit 155 and the history information of past interrupt information is higher than a threshold value.
- a process P9 determines whether the degree of similarity between the most recent interrupt information inputted from the similarity calculating unit 155 and the history information of past interrupt information is higher than a threshold value.
- the action determining unit 156 determines in process P9 that the degree of similarity is higher than the threshold (YES).
- the operation determining unit 156 determines, for example, an operation that causes the audio output device of the user interface 14 to generate a second warning sound with a lower sound pressure than the first warning sound with a normal sound pressure.
- the operation determining unit 156 may, for example, determine an operation that causes the display device of the user interface 14 to display a warning without generating a warning sound from the audio output device of the user interface 14.
- the operation determining unit 156 may determine an operation in which the actuator 13 does not decelerate the vehicle 1 and does not vibrate a vibration motor built into the seat or steering wheel.
- the motion determining section 156 outputs the determined motion to the control signal generating section 157.
- the control signal generation unit 157 executes a process P6 in which a control signal is generated based on the operation input from the operation determination unit 156 and outputted to each part of the vehicle 1. More specifically, the control signal generation unit 157 generates, for example, a control signal that causes the audio output device of the user interface 14 to generate a second warning sound with a lower sound pressure than the first warning sound with a normal sound pressure. and outputs it to the audio output device of the user interface 14. Alternatively, the control signal generation unit 157 generates a control signal that causes the display device of the user interface 14 to display a warning without generating a warning sound from the audio output device of the user interface 14, and outputs the control signal to the actuator 13. Further, the control signal generation unit 157 does not output a control signal to the actuator 13 to decelerate the vehicle 1, and does not output a control signal to vibrate the vibration motor, for example.
- a warning tone is emitted.
- no warning sound is generated from the audio output device of the user interface 14 of the vehicle 1, and a warning is displayed on the display device of the user interface 14.
- the vehicle 1 does not decelerate and the vibration motor does not vibrate.
- the vehicle control device 15 issues a warning or notification that is more suppressed than a normal warning or notification in response to the interruption of the most recent interruption vehicle Vc3 that has a high degree of similarity to the history information of past interruption information. This suppresses a decrease in the attention of the occupants of the vehicle 1 due to excessive warnings and notifications.
- the processing flow shown in FIG. 2 ends and starts again.
- the interruption detection unit 153 determines that there is an interruption (YES), and in process P2, the interruption information of the interrupting vehicle Vc4 is recorded in the storage unit 154.
- a process P7 is executed to determine whether the number of pieces of history information is greater than a threshold value.
- the similarity calculation unit 155 executes a process P8 for calculating the similarity between the history information of past interrupt information recorded in the storage unit 154 and the latest interruption information detected by the interruption detection unit 153. do.
- the vehicle control device 15 of this embodiment is a device that controls the operation of the vehicle 1, and includes the object detection section 152, the interruption detection section 153, the storage section 154, and the similarity calculation section 155. and an operation determining section 156.
- the object detection unit 152 detects an object based on the output of the external sensor 11 mounted on the vehicle 1.
- the interruption detection unit 153 detects an interruption of an object into the path of the vehicle 1.
- the storage unit 154 records interruption information including the trajectory of the object whose interruption was detected.
- the similarity calculation unit 155 calculates the similarity between the history information of the interruption information recorded in the storage unit 154 and the latest interruption information detected by the interruption detection unit 153.
- the motion determining unit 156 determines the motion of the vehicle 1 according to the degree of similarity.
- the vehicle control device 15 of the present embodiment accumulates the history information of past interruption information of objects that cut into the path of the vehicle 1, and stores the history information of the past interruption information and the history information of the past interruption information.
- the operation of the vehicle 1 can be determined according to the degree of similarity with the latest interruption information.
- the similarity between the most recent interruption information and the historical information of past interruption information is high, it can be compared to cases where the similarity is low. Warnings and notifications can be suppressed by comparison. Therefore, according to the vehicle control device 15 of the present embodiment, it is possible to suppress a decrease in the attentiveness of the occupants of the vehicle 1 due to excessive warnings and notifications, and to improve the safety of the vehicle 1.
- the operation determining unit 156 determines the operation of the user interface 14 mounted on the vehicle 1 according to the degree of similarity.
- the vehicle control device 15 of the present embodiment performs audio output or display on the user interface 14 accordingly when the degree of similarity is low, and outputs audio or displays information accordingly on the user interface 14 when the degree of similarity is high. It becomes possible to perform audio output and display using the user interface 14. Therefore, according to the vehicle control device 15 of the present embodiment, it is possible to suppress a decrease in the attentiveness of the occupants of the vehicle 1 due to excessive warnings and notifications, and to improve the safety of the vehicle 1.
- the operation determining unit 156 when the similarity is higher than the threshold, compares the similarity with the case where the similarity is equal to or lower than the threshold, Restrict the operation of the user interface 14.
- the degree of similarity between the history information of past interrupt information and the most recent interruption information is higher than a threshold value, warnings and notifications from the user interface 14 are suppressed compared to cases where the degree of similarity is less than the threshold value. can do. Therefore, according to the vehicle control device 15 of the present embodiment, it is possible to suppress a decrease in the attentiveness of the occupants of the vehicle 1 due to excessive warnings and notifications, and to improve the safety of the vehicle 1.
- the user interface 14 performs the first operation of generating the first warning sound and the second warning sound having a lower sound pressure than the first warning sound, as described above. and a second action of generating the sound. Further, the action determining unit 156 determines the first action to be performed by the audio output device when the similarity is lower than the threshold, and outputs the audio when the similarity is equal to or higher than the threshold. determining the second operation by the device;
- the vehicle control device 15 of the present embodiment causes the audio output device of the user interface 14 to output a first warning sound to be generated when the similarity is lower than the threshold when the similarity is equal to or higher than the threshold. In comparison, it is possible to generate a second warning sound with a lower sound pressure. Therefore, according to the vehicle control device 15 of the present embodiment, the sound pressure of the warning sound from the audio output device is suppressed when the degree of similarity is greater than or equal to the threshold value, and the alertness of the occupant of the vehicle 1 is reduced due to excessive warnings and notifications. This makes it possible to suppress a decrease in the temperature and improve the safety of the vehicle 1.
- the user interface 14 includes an audio output device and a display device, as described above. Further, as described above, the operation determining unit 156 determines that the audio output device generates a warning sound when the similarity is lower than the threshold, and the similarity is equal to or higher than the threshold. In this case, it is decided to display a warning on the display device.
- the vehicle control device 15 of the present embodiment can display a warning on the display device without generating a warning sound using the audio output device of the user interface 14 when the degree of similarity is greater than or equal to the threshold value. . Therefore, according to the vehicle control device 15 of the present embodiment, the generation of the warning sound by the audio output device is restricted when the degree of similarity is equal to or higher than the threshold value, and the attentiveness of the occupants of the vehicle 1 is reduced due to excessive warnings and notifications. It becomes possible to suppress the decline and improve the safety of the vehicle 1.
- Vehicle 11 External sensor 14
- Vehicle control device 152 Object detection section 153 Interruption detection section 154
- Storage section 155 Similarity calculation section Vc1 Interrupting vehicle (object)
- Vc2 Interrupting vehicle (target object)
- Vc3 Interrupting vehicle (target object)
- Vc4 Interrupting vehicle (target object)
Landscapes
- Engineering & Computer Science (AREA)
- Automation & Control Theory (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Human Computer Interaction (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Control Of Driving Devices And Active Controlling Of Vehicle (AREA)
- Traffic Control Systems (AREA)
- Auxiliary Drives, Propulsion Controls, And Safety Devices (AREA)
Abstract
本開示は、過度な警告や通知による乗員の注意力の低下を抑制することが可能な車両制御装置を提供する。車両1の動作を制御する車両制御装置15であって、対象物検知部152と、割込検知部153と、記憶部154と、類似度算出部155と、動作決定部156と、を備えている。対象物検知部152は、車両1に搭載された外界センサ11の出力に基づいて対象物を検知する。割込検知部153は、車両1の進路に対する対象物の割り込みを検知する。記憶部154は、割り込みが検知された対象物の軌跡を含む割込情報を記録する。類似度算出部155は、記憶部154に記録された割込情報の履歴情報と割込検知部153によって検知された直近の割込情報との類似度を算出する。動作決定部156は、類似度に応じて車両1の動作を決定する。
Description
本開示は、車両制御装置に関する。
従来から車両制御システムに関する発明が知られている。たとえば、下記特許文献1に記載された車両制御システムは、認識部と、特定部と、走行制御部と、を備える(第0006段落、請求項1、要約、および図1)。上記認識部は、自車両が存在する第1車線と異なる第2車線に存在する一以上の周辺車両を認識する。
上記特定部は、上記認識部により認識された周辺車両について、自車両の前方への割込確率に基づく指標値を導出し、導出した指標値が閾値以上の周辺車両を割込車両として特定する。上記走行制御部は、上記特定部により特定された割込車両の存在に応じて自車両を減速させる。この走行制御部は、自車両を減速させる際に、対象となる割込車両の上記指標値に基づいて、自車両の減速度の変化の度合を決定する。
この従来の車両制御システムによれば、自車両の前方への割込確率に基づく指標値が閾値以上の周辺車両を割込車両として特定する。そして、割込車両の存在に応じて自車両を減速させる際に、対象となる割込車両の指標値に基づいて、自車両の減速度の変化の度合を決定する。これにより、周辺車両の割り込みに応じて適切な速度制御を行うことができる(特許文献1、第0015段落)。
たとえば、上記従来の車両制御システムのように割込車両が特定された場合や自車両を減速させる際には、通常、車両のユーザインタフェースを介し、車両の乗員に対して音声や表示による警告や通知が行われる。そのため、たとえば、交通渋滞など、頻繁に割り込みが発生するような状況では、警告や通知が頻繁に発せられることで、自車両の乗員の注意力が散漫になり、安全性が低下するおそれがある。
本開示は、過度な警告や通知による乗員の注意力の低下を抑制することが可能な車両制御装置を提供する。
本開示の一態様は、車両の動作を制御する車両制御装置であって、前記車両に搭載された外界センサの出力に基づいて対象物を検知する対象物検知部と、前記車両の進路に対する前記対象物の割り込みを検知する割込検知部と、前記割り込みが検知された前記対象物の軌跡を含む割込情報を記録する記憶部と、前記記憶部に記録された前記割込情報の履歴情報と前記割込検知部によって検知された直近の前記割込情報との類似度を算出する類似度算出部と、前記類似度に応じて前記車両の動作を決定する動作決定部と、を備えることを特徴とする車両制御装置である。
本開示によれば、過度な警告や通知による乗員の注意力の低下を抑制することが可能な車両制御装置を提供することができる。
以下、図面を参照して本開示に係る車両制御装置の実施形態を説明する。
図1は、本開示に係る車両制御装置の実施形態を示すブロック図である。本実施形態の車両制御装置15は、たとえば、車両1に搭載され、車両1の各部の動作を制御する電子制御ユニット(ECU)である。車両1は、たとえば、外界センサ11と、車両センサ12と、アクチュエータ13と、ユーザインタフェース14と、車両制御装置15とを備えている。
外界センサ11は、たとえば、撮像装置を含む。撮像装置は、たとえば、単眼カメラとステレオカメラの少なくとも一方を含む。また、外界センサ11は、たとえば、LiDAR(レーザレーダ)、ミリ波レーダ、超音波センサ、または赤外線センサの少なくとも一つを含むことができる。外界センサ11は、たとえば、車両1の周囲の物体を検出し、検出結果を外界センサ情報として車両制御装置15へ出力する。
車両センサ12は、たとえば、位置センサ、速度センサ、加速度センサ、ヨーレートセンサ、エンジン回転センサ、操舵角センサ、ギアポジションセンサ、およびペダルストロークセンサなどを含む。位置センサは、たとえば、全球測位衛星システム(GNSS)の受信機を含む。速度センサは、たとえば、車輪速センサを含む。車両センサ12は、たとえば、車両1の位置、速度、加速度などを含む車両情報を検出し、検出結果を車両センサ情報として車両制御装置15へ出力する。
アクチュエータ13は、たとえば、スロットルバルブの開閉、ブレーキの操作、変速機の操作、またはステアリングの操作など、車両1の各部の操作を行う各種のアクチュエータを含む。アクチュエータ13は、たとえば、車両制御装置15から入力される制御信号に基づいて車両1の各部を操作する。
ユーザインタフェース14は、たとえば、音声出力装置と、表示装置とを含む。音声出力装置は、たとえば、スピーカやブザーなどを含む。表示装置は、たとえば、ヘッドアップディスプレイ、液晶表示装置、有機EL表示装置、インストルメントパネル、または表示ランプの少なくとも一つを含む。また、ユーザインタフェース14は、たとえば、シートやステアリングに内蔵された振動モータを含んでもよい。
車両制御装置15は、たとえば、一つ以上のマイクロコントローラ(MCU)を含み、中央処理装置(CPU)、RAMやROMなどのメモリ、タイマー、および入出力部などを含む。また、車両制御装置15は、たとえば、ハードディスクなどの記憶装置を含んでもよい。車両制御装置15は、たとえば、外界センサ11または車両センサ12の少なくとも一方の出力に基づいて、車両1のアクチュエータ13またはユーザインタフェース14の少なくとも一方を含む車両1の各部を制御する。
車両制御装置15は、たとえば、図1に示すように、センサ情報取得部151と、対象物検知部152と、割込検知部153と、記憶部154と、類似度算出部155と、動作決定部156と、制御信号生成部157と、を有している。これら車両制御装置15の各部は、たとえば、車両制御装置15のメモリや記憶装置に記憶されたプログラムをCPUによって実行することで実現される車両制御装置15の各機能を表している。なお、車両制御装置15の各部は、たとえば、一つまたは複数の部分を一つの装置によって構成してもよく、一つの部分を複数の装置によって構成してもよい。
以下、図2および図3を参照して、本実施形態の車両制御装置15の動作を説明する。図2は、図1に示す車両制御装置15の動作を説明するフロー図である。図3は、図1に示す車両1の進路に対する対象物の割り込みを説明する平面図である。
車両制御装置15は、図2に示す処理フローを開始すると、まず、車両1の進路に対する対象物の割り込みの有無を判定する処理P1を実行する。ここで、対象物は、たとえば、自車両である車両1の進路に進入する乗用車、バス、またはトラックなどの車両、自動二輪車、自転車、荷車、歩行者、もしくは動物などの移動体を含む。
この処理P1において、車両制御装置15のセンサ情報取得部151は、たとえば、車両1に搭載された外界センサ11の出力である外界センサ情報を取得する。より具体的には、センサ情報取得部151は、たとえば、外界センサ11に含まれる単眼カメラまたはステレオカメラから外界センサ情報としての画像を取得し、さらなる処理のために画像特性を調整する。
この画像特性の調整処理は、たとえば、画像をダウンスケールまたはアップスケールし、結果として得られる画像サイズを変更する画像解像度調整処理や、入力画像の所定の領域を切り取るクロッピングを行う画像関心領域選択処理などを含む。これらの処理に使用されるパラメータは、たとえば、車両1の走行環境、速度、旋回速度などに応じて、適宜変更することができる。センサ情報取得部151は、たとえば、これらの処理を行った処理画像を含む外界センサ情報を対象物検知部152へ出力する。
また、センサ情報取得部151は、たとえば、車両センサ12の出力である車両センサ情報を取得する。センサ情報取得部151は、たとえば、外界センサ11および車両センサ12から取得した外界センサ情報および車両センサ情報を含むセンサ情報を、対象物検知部152および動作決定部156へ出力する。
さらに、この処理P1において、対象物検知部152は、センサ情報取得部151から入力された外界センサ情報に基づいて対象物を検知する。より詳細には、対象物検知部152は、たとえば、センサ情報取得部151から入力された外界センサ情報に含まれる処理画像を用いて、予め学習させた分類器を用いて、車両を含む対象物の検出を行う。分類器は、たとえば、畳み込みニューラルネットワーク、パターンマッチング、決定木などを含む。
対象物検知部152は、検知した対象物のうち、自動車、トラック、バス、自動二輪車など、車両に分類される対象物を、その対象物に関する特徴量とともに、割込検知部153へ出力する。ここで、対象物に関する特徴量は、たとえば、対象物の位置や速度を含むが、対象物の軌跡や対象物の種別などを含むこともできる。本実施形態において、対象物の検知とは、たとえば、少なくとも、対象物の位置、対象物の種別、3次元空間における車両1から対象物までの距離、および対象物の速度を算出する処理を意味する。また、対象物検知部152は、たとえば、外界センサ11の出力に基づいて検出した車両1の周囲の物体の情報を、動作決定部156へ出力する。
さらに、この処理P1において、割込検知部153は、車両1の進路に対する対象物の割り込みを検知する。図2に示すように、処理P1において、割込検知部153によって対象物の割り込みが判定されなかった場合(NO)、車両制御装置15は、図2に示す処理フローを終了する。車両制御装置15は、たとえば、図2に示す処理フローを所定の周期で繰り返し実行する。その後、図3に示すように、時刻T=T1において、車両1が走行している車線の隣の車線から、車両1と先行車両Va1との間の車両1の進路に対して、割込車両Vc1が割り込んだとする。
割込検知部153は、たとえば、対象物検知部152から入力された割込車両Vc1の特徴量に含まれる横方向速度が、車両1の進路の所定の区間で、所定の時間にわたって、所定の閾値を超えた場合に、割込車両Vc1が割り込んだことを判定する。割込車両Vc1の割り込みを判定するための閾値は、たとえば、車両1の走行状態や割込車両Vc1の種類に応じて設定される。そして、たとえば、時刻T=T1に実行された処理P1において、割込検知部153によって割込車両Vc1の割り込みが判定されると(YES)、車両制御装置15は、割込情報を記録する処理P2を実行する。
この処理P2において、記憶部154は、たとえば、割り込みが検知された対象物の軌跡を含む割込情報を記録する。より詳細には、この処理P2において、割込検知部153は、たとえば、対象物検知部152から入力された対象物の位置および速度を含む特徴量と、カーブフィッティングなどの軌跡生成方法を用いて割込車両Vc1の軌跡を算出する。割込検知部153は、算出した割込車両Vc1の軌跡を、割り込みが検知された時刻T=T1とともに、記憶部154へ出力する。
記憶部154は、たとえば、割込検知部153から入力された割込車両Vc1の軌跡および時刻T=T1を含む対象物の割込情報を記録する。なお、記憶部154に記録される対象物の割込情報は、たとえば、対象物の位置、速度、移動方向、および種別など、対象物の軌跡以外の情報を含んでいてもよい。記憶部154は、たとえば、メモリや記憶装置に記録された割込情報を、所定の期間の経過後に削除する。割込情報を削除する所定の期間は、たとえば、車両1の走行条件によって異なるタイムスタンプの有効期限に基づいて設定される。
その後、車両制御装置15は、図2に示すように、割込情報の履歴の有無を判定する処理P3を実行する。この処理P3において、類似度算出部155は、たとえば、記憶部154に記録された割込情報の履歴情報の有無を判定する。たとえば、前述のように、直近の時刻T=T1で記録された割込情報の他に、記憶部154に過去の割込情報が記録されていない場合、類似度算出部155は、処理P3において、割込情報の履歴情報がないこと(NO)を判定する。この場合、類似度算出部155は、たとえば、新しい割込情報と過去の割込情報の履歴情報との類似度をゼロに設定し、設定した類似度を動作決定部156へ出力する。
その後、動作決定部156は、類似度算出部155から入力された類似度に基づいて、直近の時刻T=T1における割込車両Vc1の割込情報に優先度を付与する処理P4を実行する。ここでは、前の処理P3において、時刻T=T1における割込車両Vc1の割込情報に類似する過去の割込情報の履歴情報が存在せず、類似度がゼロに設定されている。そのため、動作決定部156は、直近の時刻T=T1における割込車両Vc1の割込情報に、過去の割込情報の履歴情報との低い類似度に応じた高い優先度を付与する。
その後、動作決定部156は、たとえば、直近の時刻T=T1における割込車両Vc1の割込情報に付与した優先度に基づいて、車両1の各部の動作を決定する処理P5を実行する。この処理P5において、動作決定部156は、直近の割込情報に付与した高優先度に基づいて、アクチュエータ13およびユーザインタフェース14を含む車両の各部の動作を決定する。
より具体的には、動作決定部156は、たとえば、ユーザインタフェース14の音声出力装置から、通常の音圧の第1警告音を発生させる動作を決定する。また、動作決定部156は、たとえば、ユーザインタフェース14の表示装置に、警告を表示させる動作を決定する。また、動作決定部156は、たとえば、車両1を減速させるアクチュエータ13の動作や、シートやステアリングに内蔵された振動モータを振動させる動作を決定してもよい。動作決定部156は、決定した動作を制御信号生成部157へ出力する。
その後、制御信号生成部157は、動作決定部156から入力された動作に基づく制御信号を生成して、車両1の各部へ出力する処理P6を実行する。より具体的には、制御信号生成部157は、たとえば、ユーザインタフェース14の音声出力装置から通常の音圧の第1警告音を発生させる制御信号を生成して、ユーザインタフェース14の音声出力装置へ出力する。
また、制御信号生成部157は、たとえば、ユーザインタフェース14の表示装置に警告を表示させる制御信号を生成して、ユーザインタフェース14の表示装置へ出力する。また、制御信号生成部157は、たとえば、アクチュエータ13に車両1を減速させる動作をさせる制御信号を生成して、アクチュエータ13へ出力する。また、制御信号生成部157は、たとえば、シートやステアリングに内蔵された振動モータを振動させる制御信号を生成して、振動モータへ出力する。
その結果、図3に示す時刻T=T1における割込車両Vc1の割り込みに対し、たとえば、車両1のユーザインタフェース14の音声出力装置から通常の音圧の第1警告音が発せられ、ユーザインタフェース14の表示装置に警告が表示される。また、たとえば、車両1のアクチュエータ13が動作して車両1を減速させ、ステアリングやシートに内蔵された振動モータが振動する。このように、車両制御装置15は、過去の割込情報の履歴情報に類似しない割り込みに対して、通常の警告や通知を行って車両1の乗員の注意を喚起する。
その後、図2に示す処理フローが終了し、再び開始される。その後、図3に示すように、時刻T=T2において、車両1と先行車両Va2との間の車両1の進路に割込車両Vc2が割り込んだとする。この場合、時刻T=T1における処理フローと同様に、処理P1において、割込検知部153によって割り込みあり(YES)と判定され、処理P2において、記憶部154に割込車両Vc2の割込情報が記録される。
その後、処理P3において、記憶部154に時刻T=T1の割込情報の履歴情報が記憶されていることから、類似度算出部155は、割込情報の履歴あり(YES)と判定し、履歴情報の数が閾値よりも多いか否かを判定する処理P7を実行する。ここで、たとえば、履歴情報の数の閾値が1である場合、類似度算出部155は、記憶部154に過去の割込情報の履歴情報が時刻T=T1の一つしか記録されていないため、処理P7で履歴情報の数が閾値以下である(NO)と判定する。
この場合、比較対象の過去の割込情報の履歴情報の数が不十分であることから、類似度算出部155は、たとえば、前述の時刻T=T1における割込車両Vc1の割り込みと同様に、直近の時刻T=T2の割込車両Vc2の割込情報と過去の履歴情報の類似度をゼロに設定する。類似度算出部155は、設定した類似度を動作決定部156へ出力する。その後、前述の時刻T=T1における処理フローと同様に、処理P4において、動作決定部156は、類似度算出部155から入力された過去の割込情報の履歴情報との低い類似度に応じて、直近の時刻T=T2の割込車両Vc2の割込情報に高優先度を付与する。
その結果、前述の時刻T=T1における処理フローと同様に、処理P5およびP6を経て、図3に示す時刻T=T2における割込車両Vc2の割り込みに対し、たとえば、車両1のユーザインタフェース14の音声出力装置から通常の音圧の第1警告音が発せられる。また、ユーザインタフェース14の表示装置に警告が表示され、車両1のアクチュエータ13が動作して車両1を減速させ、シートやステアリングに内蔵された振動モータが振動する。このように、車両制御装置15は、過去の割込情報の履歴情報の数が十分でない場合に、直近の対象物の割り込みに対して通常の警告や通知を行って車両1の乗員の注意を喚起する。
その後、図2に示す処理フローが終了し、再び開始される。その後、図3に示すように、時刻T=T3において、車両1と先行車両Va3との間の車両1の進路に割込車両Vc3が割り込んだとする。この場合、処理P1において、割込検知部153によって割り込みあり(YES)と判定され、処理P2において、記憶部154に割込車両Vc3の割込情報が記録される。
その後、処理P3において、類似度算出部155は、記憶部154に時刻T=T1,T2の二つの割込情報の履歴情報が記憶されていることから、割込情報の履歴あり(YES)と判定し、履歴情報の数が閾値よりも多いか否かを判定する処理P7を実行する。ここでは、記憶部154に過去の時刻T=T1,T2の二つの割込情報の履歴情報が記録されている。そのため、処理P7において、たとえば、履歴情報の数の閾値が1である場合、類似度算出部155は、履歴情報の数が閾値より大である(YES)と判定する。
その後、類似度算出部155は、記憶部154に記録された過去の割込情報の履歴情報と割込検知部153によって検知された直近の割込情報との類似度を算出する処理P8を実行する。この処理P8において、類似度算出部155は、たとえば、直近の割込情報に含まれる軌跡と、過去の割込情報の履歴情報に含まれる軌跡との間のユークリッド距離に基づいて、下記の式(1)により類似度の損失を算出する。
損失=Σ(重み×比較結果) ・・・(1)
上記の式(1)の重みは、過去の割込情報の履歴情報のそれぞれに割り当てられ、たとえば、割り込み発生時刻からの経過時間が短いほど大きく、割り込み発生時刻からの経過時間が長いほど小さくなる。また、上記の式(1)の比較結果は、たとえば、直近の割込情報の軌跡と、過去の割込情報の軌跡とのユークリッド距離が閾値より小さい場合に0となり、閾値以上の場合に1となる。類似度算出部155は、たとえば、過去のすべての割込情報の履歴情報に対して、類似度の損失を算出する。
類似度算出部155は、たとえば、直近の割込情報と過去の割込情報との間の類似度の損失が所定の類似度定数よりも小さい場合に、その直近の割込情報に対して高い類似度を割り当てる。また、類似度算出部155は、たとえば、直近の割込情報と過去の割込情報との間の類似度の損失が所定の類似度定数以上である場合に、その割込情報に対して低い類似度を割り当てる。類似度算出部155は、直近の割込情報に割り当てた類似度を動作決定部156へ出力する。
その後、動作決定部156は、類似度算出部155から入力された直近の割込情報と過去の割込情報の履歴情報との類似度が、閾値よりも高いか否かを判定する処理P9を実行する。ここでは、図3に示すように、過去の時刻T=T1,T2における割込車両Vc1,Vc2の割込情報と、直近の時刻T3における割込車両Vc3の割込情報が類似し、直近の割込情報に高い類似度が割り当てられている。この場合、動作決定部156は、処理P9において、類似度が閾値よりも高いこと(YES)を判定する。
その後、動作決定部156は、直近の割込情報に対し、過去の割込情報との高い類似度に応じた低い優先度を付与する処理P10を実行する。その後、動作決定部156は、直近の時刻T=T3における割込情報に付与した優先度に基づいて、車両1の各部の動作を決定する処理P5を実行する。この処理P5において、動作決定部156は、割込情報に付与した低優先度に基づいて、アクチュエータ13およびユーザインタフェース14を含む車両1の各部の動作を決定する。
より具体的には、動作決定部156は、たとえば、ユーザインタフェース14の音声出力装置から、通常の音圧の第1警告音よりも低い音圧の第2警告音を発生させる動作を決定する。または、動作決定部156は、たとえば、ユーザインタフェース14の音声出力装置から警告音を発生させず、ユーザインタフェース14の表示装置に警告を表示させる動作を決定してもよい。また、動作決定部156は、たとえば、アクチュエータ13によって車両1を減速させず、シートやステアリングに内蔵された振動モータを振動させない動作を決定してもよい。動作決定部156は、決定した動作を制御信号生成部157へ出力する。
その後、制御信号生成部157は、動作決定部156から入力された動作に基づく制御信号を生成して、車両1の各部へ出力する処理P6を実行する。より具体的には、制御信号生成部157は、たとえば、ユーザインタフェース14の音声出力装置から通常の音圧の第1警告音よりも低い音圧の第2警告音を発生させる制御信号を生成して、ユーザインタフェース14の音声出力装置へ出力する。または、制御信号生成部157は、たとえば、ユーザインタフェース14の音声出力装置から警告音を発生させず、ユーザインタフェース14の表示装置に警告を表示させる制御信号を生成して、アクチュエータ13へ出力する。また、制御信号生成部157は、たとえば、アクチュエータ13に車両1を減速させる制御信号を出力せず、振動モータを振動させる制御信号を出力しない。
その結果、図3に示す時刻T=T3における割込車両Vc3の割り込みに対し、たとえば、車両1のユーザインタフェース14の音声出力装置から通常の音圧の第1警告音よりも低い音圧の第2警告音が発せられる。または、たとえば、車両1のユーザインタフェース14の音声出力装置から警告音が発生されず、ユーザインタフェース14の表示装置に警告が表示される。また、車両1は減速せず、振動モータも振動しない。このように、車両制御装置15は、過去の割込情報の履歴情報に対する類似度が高い直近の割込車両Vc3の割り込みに対して、通常の警告や通知よりも抑制された警告や通知を行って、過度の警告や通知による車両1の乗員の注意低下を抑制する。
その後、図2に示す処理フローが終了し、再び開始される。その後、図3に示すように、時刻T=T4において、車両1と先行車両Va4との間の車両1の進路に割込車両Vc4が割り込んだとする。この場合、処理P1において、割込検知部153によって割り込みあり(YES)と判定され、処理P2において、記憶部154に割込車両Vc4の割込情報が記録される。
その後、処理P3において、類似度算出部155は、記憶部154に時刻T=T1,T2,T3の割込情報の履歴情報が記憶されていることから、割込情報の履歴あり(YES)と判定し、履歴情報の数が閾値よりも多いか否かを判定する処理P7を実行する。ここでは、記憶部154に過去の割込情報の履歴情報が時刻T=T1,T2,T3の三つ記録されている。そのため、たとえば、履歴情報の数の閾値が1である場合、類似度算出部155は、処理P7において、履歴情報の数が閾値より大である(YES)と判定する。
その後、類似度算出部155は、記憶部154に記録された過去の割込情報の履歴情報と割込検知部153によって検知された直近の割込情報との類似度を算出する処理P8を実行する。図3に示す時刻T=T4における割込車両Vc4の割り込みの方向は、過去の時刻T1,T2,T3の割込車両Vc1,Vc2,Vc3の割り込みの方向と異なっている。そのため、類似度算出部155が、直近の時刻T=T4の割込情報に割り当てる類似度は、低くなる。
その結果、処理P9において、動作決定部156は、たとえば、類似度算出部155から入力された類似度が閾値よりも低いこと(NO)を判定する。その後、処理P4において、動作決定部156は、直近の時刻T=T4の割込車両Vc4の割込情報の閾値よりも低い類似度に応じて、直近の割込情報に高優先度を付与する。
その結果、処理P5およびP6を経て、図3に示す時刻T=T4における割込車両Vc4の割り込みに対し、たとえば、車両1のユーザインタフェース14の音声出力装置から通常の音圧の第1警告音が発せられ、ユーザインタフェース14の表示装置に警告が表示される。また、車両1のアクチュエータ13が動作して車両1を減速させ、シートやステアリングに内蔵された振動モータが振動する。このように、車両制御装置15は、過去の割込情報の履歴情報と直近の割込情報との類似度が低い場合に、直近の対象物の割り込みに対して通常の警告や通知を行って車両1の乗員の注意を喚起する。
以下、本実施形態の車両制御装置15の作用を説明する。
本実施形態の車両制御装置15は、前述のように、車両1の動作を制御する装置であり、対象物検知部152と、割込検知部153と、記憶部154と、類似度算出部155と、動作決定部156と、を備えている。対象物検知部152は、車両1に搭載された外界センサ11の出力に基づいて対象物を検知する。割込検知部153は、車両1の進路に対する対象物の割り込みを検知する。記憶部154は、割り込みが検知された対象物の軌跡を含む割込情報を記録する。類似度算出部155は、記憶部154に記録された割込情報の履歴情報と割込検知部153によって検知された直近の割込情報との類似度を算出する。動作決定部156は、類似度に応じて車両1の動作を決定する。
このような構成により、本実施形態の車両制御装置15によれば、車両1の進路に割り込んだ対象物の過去の割込情報の履歴情報を蓄積し、その過去の割込情報の履歴情報と直近の割込情報との類似度に応じて、車両1の動作を決定することができる。これにより、たとえば、交通渋滞など、頻繁に割り込みが発生するような状況でも、直近の割込情報と過去の割込情報の履歴情報との類似度が高い場合には、類似度が低い場合と比較して警告や通知を抑制することができる。したがって、本実施形態の車両制御装置15によれば、過度な警告や通知による車両1の乗員の注意力の低下を抑制し、車両1の安全性を向上させることが可能になる。
また、本実施形態の車両制御装置15において、動作決定部156は、上記類似度に応じて車両1に搭載されたユーザインタフェース14の動作を決定する。このような構成により、本実施形態の車両制御装置15は、上記類似度が低い場合には、それに応じてユーザインタフェース14による音声出力や表示を行い、上記類似度が高い場合には、それに応じてユーザインタフェース14による音声出力や表示を行うことが可能になる。したがって、本実施形態の車両制御装置15によれば、過度な警告や通知による車両1の乗員の注意力の低下を抑制し、車両1の安全性を向上させることが可能になる。
また、本実施形態の車両制御装置15において、動作決定部156は、上記類似度が閾値よりも高い場合に、上記類似度が上記閾値と等しいかまたは上記閾値よりも低い場合と比較して、ユーザインタフェース14の動作を制限する。これにより、過去の割込情報の履歴情報と直近の割込情報との類似度が閾値よりも高い場合に、類似度が閾値以下の場合と比較して、ユーザインタフェース14による警告や通知を抑制することができる。したがって、本実施形態の車両制御装置15によれば、過度な警告や通知による車両1の乗員の注意力の低下を抑制し、車両1の安全性を向上させることが可能になる。
また、本実施形態の車両制御装置15において、ユーザインタフェース14は、前述のように、第1警告音を発生させる第1動作と、その第1警告音よりも音圧が低い第2警告音を発生させる第2動作とを実施可能な音声出力装置を含んでいる。また、動作決定部156は、上記類似度が上記閾値よりも低い場合に音声出力装置による上記第1動作を決定し、上記類似度が上記閾値と等しいか上記閾値よりも高い場合に上記音声出力装置による上記第2動作を決定する。
これにより、本実施形態の車両制御装置15は、上記類似度が閾値以上である場合に、ユーザインタフェース14の音声出力装置によって、上記類似度が閾値よりも低い場合に発生させる第1警告音と比較して、音圧が低い第2警告音を発生させることができる。したがって、本実施形態の車両制御装置15によれば、上記類似度が閾値以上である場合に音声出力装置による警告音の音圧を抑制し、過度な警告や通知による車両1の乗員の注意力の低下を抑制し、車両1の安全性を向上させることが可能になる。
また、本実施形態の車両制御装置15において、ユーザインタフェース14は、前述のように、音声出力装置と表示装置とを含んでいる。また、動作決定部156は、前述のように、上記類似度が閾値よりも低い場合に音声出力装置による警告音の発生を決定し、前記類似度が前記閾値と等しいかまたは前記閾値よりも高い場合に、表示装置による警告の表示を決定する。
これにより、本実施形態の車両制御装置15は、上記類似度が閾値以上である場合に、ユーザインタフェース14の音声出力装置によって警告音を発生させることなく、表示装置に警告を表示させることができる。したがって、本実施形態の車両制御装置15によれば、上記類似度が閾値以上である場合に音声出力装置による警告音の発生を制限し、過度な警告や通知による車両1の乗員の注意力の低下を抑制し、車両1の安全性を向上させることが可能になる。
以上、図面を用いて本開示に係る車両制御装置の実施形態を詳述してきたが、具体的な構成はこの実施形態に限定されるものではなく、本開示の要旨を逸脱しない範囲における設計変更等があっても、それらは本開示に含まれるものである。
1 車両
11 外界センサ
14 ユーザインタフェース
15 車両制御装置
152 対象物検知部
153 割込検知部
154 記憶部
155 類似度算出部
Vc1 割込車両(対象物)
Vc2 割込車両(対象物)
Vc3 割込車両(対象物)
Vc4 割込車両(対象物)
11 外界センサ
14 ユーザインタフェース
15 車両制御装置
152 対象物検知部
153 割込検知部
154 記憶部
155 類似度算出部
Vc1 割込車両(対象物)
Vc2 割込車両(対象物)
Vc3 割込車両(対象物)
Vc4 割込車両(対象物)
Claims (5)
- 車両の動作を制御する車両制御装置であって、
前記車両に搭載された外界センサの出力に基づいて対象物を検知する対象物検知部と、 前記車両の進路に対する前記対象物の割り込みを検知する割込検知部と、
前記割り込みが検知された前記対象物の軌跡を含む割込情報を記録する記憶部と、
前記記憶部に記録された前記割込情報の履歴情報と前記割込検知部によって検知された直近の前記割込情報との類似度を算出する類似度算出部と、
前記類似度に応じて前記車両の動作を決定する動作決定部と、
を備えることを特徴とする車両制御装置。 - 前記動作決定部は、前記類似度に応じて前記車両に搭載されたユーザインタフェースの動作を決定することを特徴とする請求項1に記載の車両制御装置。
- 前記動作決定部は、前記類似度が閾値よりも高い場合に、前記類似度が前記閾値と等しいかまたは前記閾値よりも低い場合と比較して、前記ユーザインタフェースの動作を制限することを特徴とする請求項2に記載の車両制御装置。
- 前記ユーザインタフェースは、第1警告音を発生させる第1動作と、前記第1警告音よりも音圧が低い第2警告音を発生させる第2動作とを実施可能な音声出力装置を含み、
前記動作決定部は、前記類似度が前記閾値よりも低い場合に前記音声出力装置による前記第1動作を決定し、前記類似度が前記閾値と等しいか前記閾値よりも高い場合に前記音声出力装置による前記第2動作を決定することを特徴とする請求項3に記載の車両制御装置。 - 前記ユーザインタフェースは、音声出力装置と表示装置とを含み、
前記動作決定部は、前記類似度が閾値よりも低い場合に前記音声出力装置による警告音の発生を決定し、前記類似度が前記閾値と等しいかまたは前記閾値よりも高い場合に、前記表示装置による警告の表示を決定することを特徴とする請求項2に記載の車両制御装置。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2022108759A JP7784963B2 (ja) | 2022-07-06 | 2022-07-06 | 車両制御装置 |
| JP2022-108759 | 2022-07-06 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024009583A1 true WO2024009583A1 (ja) | 2024-01-11 |
Family
ID=89452991
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2023/015160 Ceased WO2024009583A1 (ja) | 2022-07-06 | 2023-04-14 | 車両制御装置 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP7784963B2 (ja) |
| WO (1) | WO2024009583A1 (ja) |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003281700A (ja) * | 2002-03-25 | 2003-10-03 | Toshiba Corp | 割り込み車両検出装置及びその方法 |
| JP2003288691A (ja) * | 2002-03-27 | 2003-10-10 | Toyota Central Res & Dev Lab Inc | 割り込み予測装置 |
| WO2021166744A1 (ja) * | 2020-02-19 | 2021-08-26 | 日本電気株式会社 | 走行状態判定装置、割込み警告装置、方法、及びコンピュータ可読媒体 |
-
2022
- 2022-07-06 JP JP2022108759A patent/JP7784963B2/ja active Active
-
2023
- 2023-04-14 WO PCT/JP2023/015160 patent/WO2024009583A1/ja not_active Ceased
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2003281700A (ja) * | 2002-03-25 | 2003-10-03 | Toshiba Corp | 割り込み車両検出装置及びその方法 |
| JP2003288691A (ja) * | 2002-03-27 | 2003-10-10 | Toyota Central Res & Dev Lab Inc | 割り込み予測装置 |
| WO2021166744A1 (ja) * | 2020-02-19 | 2021-08-26 | 日本電気株式会社 | 走行状態判定装置、割込み警告装置、方法、及びコンピュータ可読媒体 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7784963B2 (ja) | 2025-12-12 |
| JP2024007597A (ja) | 2024-01-19 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6369488B2 (ja) | 車両制御装置 | |
| CN108263279B (zh) | 基于传感器整合的行人检测和行人碰撞避免装置及方法 | |
| US9656667B2 (en) | Method for minimizing automatic braking intrusion based on collision confidence | |
| JP6611085B2 (ja) | 車両制御装置 | |
| JP6592074B2 (ja) | 車両制御装置、車両制御方法、プログラム、および情報取得装置 | |
| CN104149786B (zh) | 车辆控制装置、车辆以及车辆控制方法 | |
| US9406230B2 (en) | Drive control apparatus | |
| CN113119725B (zh) | 驾驶支援装置 | |
| US20170341648A1 (en) | Autonomous driving control apparatus, driving information output apparatus, footrest, autonomous driving control method, and driving information output method | |
| KR20150051548A (ko) | 운전자의 성향을 반영하는 운전보조시스템 및 그 제어방법 | |
| KR101552017B1 (ko) | 성능이 개선된 운전보조시스템 및 그 제어방법 | |
| JP2016101893A (ja) | 衝突回避装置 | |
| JP2019043290A (ja) | 車両制御装置 | |
| JP2003288691A (ja) | 割り込み予測装置 | |
| JP7822295B2 (ja) | 制御装置、制御方法、およびプログラム | |
| JP2022145240A (ja) | 運転支援装置 | |
| US11403948B2 (en) | Warning device of vehicle and warning method thereof | |
| US20240331315A1 (en) | Method for ascertaining a configuration of a user-state-dependent output of information for a user of an ar device, and ar device | |
| JP2023138401A (ja) | 自車両用支援システムおよび方法 | |
| JP7584341B2 (ja) | 車両用シートベルト装置、張力制御方法、およびプログラム | |
| JP2023138401A5 (ja) | ||
| KR101511860B1 (ko) | 운전보조시스템 및 그 제어방법 | |
| JP7784963B2 (ja) | 車両制御装置 | |
| JP7650913B2 (ja) | 車両用制御装置、車両制御方法、およびプログラム | |
| KR101511863B1 (ko) | 타이어 공기압을 고려한 긴급제동 장치 및 그 제어방법 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 23835124 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 23835124 Country of ref document: EP Kind code of ref document: A1 |