WO2023120479A1 - 測距装置および測距方法 - Google Patents
測距装置および測距方法 Download PDFInfo
- Publication number
- WO2023120479A1 WO2023120479A1 PCT/JP2022/046682 JP2022046682W WO2023120479A1 WO 2023120479 A1 WO2023120479 A1 WO 2023120479A1 JP 2022046682 W JP2022046682 W JP 2022046682W WO 2023120479 A1 WO2023120479 A1 WO 2023120479A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- light
- saturated
- distance measuring
- peak position
- measuring device
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images





Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S17/00—Systems using the reflection or reradiation of electromagnetic waves other than radio waves, e.g. lidar systems
- G01S17/02—Systems using the reflection of electromagnetic waves other than radio waves
- G01S17/06—Systems determining position data of a target
- G01S17/08—Systems determining position data of a target for measuring distance only
- G01S17/10—Systems determining position data of a target for measuring distance only using transmission of interrupted, pulse-modulated waves
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/48—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S17/00
- G01S7/483—Details of pulse systems
- G01S7/486—Receivers
- G01S7/4865—Time delay measurement, e.g. time-of-flight measurement, time of arrival measurement or determining the exact position of a peak
- G01S7/4866—Time delay measurement, e.g. time-of-flight measurement, time of arrival measurement or determining the exact position of a peak by fitting a model or function to the received signal
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S17/00—Systems using the reflection or reradiation of electromagnetic waves other than radio waves, e.g. lidar systems
- G01S17/02—Systems using the reflection of electromagnetic waves other than radio waves
- G01S17/06—Systems determining position data of a target
- G01S17/42—Simultaneous measurement of distance and other co-ordinates
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/48—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S17/00
- G01S7/4802—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S17/00 using analysis of echo signal for target characterisation; Target signature; Target cross-section
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/48—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S17/00
- G01S7/483—Details of pulse systems
- G01S7/486—Receivers
- G01S7/4865—Time delay measurement, e.g. time-of-flight measurement, time of arrival measurement or determining the exact position of a peak
Definitions
- the present invention relates to a ranging device and a ranging method.
- Patent Document 1 describes detecting a rising edge of a saturated received signal.
- a first polynomial curve is fitted to a plurality of samples including the maximum sample of a received signal, etc., the maximum value of the first polynomial curve is determined, and a predetermined percentage of the maximum value is converted to an intermediate value.
- Define threshold The point of the first polynomial curve that crosses the intermediate threshold magnitude is then determined, and the samples of the received signal near that point are the intermediate samples.
- a second polynomial curve is then footed to the intermediate samples. Then, determine the point at which the second polynomial and the intermediate threshold intersect.
- Patent Document 2 states that when the received signal is saturated, the signal strength can be obtained by referring to the correlation based on the pulse width of the received signal.
- One example of the problem to be solved by the present invention is to estimate the peak position of a saturated received light waveform with a small processing load.
- a distance measuring device that detects pulsed light emitted from a light source and reflected by an object with a light receiving unit, an estimating unit for estimating a peak position of the pulsed light using a saturated waveform generated by the light receiving unit that received the pulsed light and partially saturated with the received light signal;
- the estimation unit Among the saturated waveforms, specifying a temporary peak position using a plurality of data points including the starting point of saturation, Identifying a correction parameter based on the saturation width of the saturated waveform;
- the distance measuring device estimates the peak position of the pulsed light by correcting the temporary peak position using the specified correction parameter.
- a distance measurement method in which pulsed light emitted from a light source and reflected by an object is detected by a light receiving unit An estimating step of estimating a peak position of the pulsed light using a saturated waveform, which is a received light waveform generated by the light receiving unit that received the pulsed light and in which the received light signal is partially saturated,
- the estimation step Among the saturated waveforms, specifying a temporary peak position using a plurality of data points including the starting point of saturation, Identifying a correction parameter based on the saturation width of the saturated waveform;
- a distance measurement method for estimating the peak position of the pulsed light by correcting the temporary peak position using the specified correction parameter A distance measurement method for estimating the peak position of the pulsed light by correcting the temporary peak position using the specified correction parameter.
- FIG. 1 is a diagram illustrating in detail the configuration of a distance measuring device according to a first embodiment;
- FIG. It is a figure which illustrates the hardware constitutions of the distance measuring device which concerns on 1st Embodiment.
- FIG. 4 is a diagram showing an example of a light receiving signal generated by a light receiving section; 4 is a waveform illustrating a saturated object peak; It is a figure which illustrates the saturation width of a saturated waveform. It is a figure which shows an example of reference information.
- FIG. 4 is a diagram showing an example of a light receiving signal generated by a light receiving section; 4 is a waveform illustrating a saturated object peak; It is a figure which illustrates the saturation width of a saturated waveform. It is a figure which shows an example of reference information.
- FIG. 10 is a diagram showing another example of reference information
- 6 is a flowchart illustrating the flow of processing performed by an estimation unit according to the first embodiment
- It is a figure for demonstrating the process which the estimation part which concerns on 1st Embodiment performs.
- It is a figure which illustrates a light reception signal when a target object exists in a close distance from a range finder.
- FIG. 4 illustrates a waveform of a saturated single object peak
- FIG. 10 is a diagram illustrating waveforms when a saturated object peak and an internal reflection peak are combined due to the presence of an object at a close distance of the range finder.
- It is a figure which illustrates the reference information which concerns on 2nd Embodiment.
- FIG. 1 is a diagram illustrating the functional configuration of a distance measuring device 10 according to the first embodiment.
- the distance measuring device 10 is a device that detects the pulsed light emitted from the light source 14 and reflected by the object 30 with the light receiving section 180 .
- the ranging device 10 has an estimating section 121 .
- the estimating unit 121 estimates the peak position of the pulsed light using a saturated waveform, which is a received light waveform in which the received light signal is partially saturated, generated by the light receiving unit 180 that received the pulsed light.
- the estimation unit 121 identifies the temporary peak position using a plurality of data points including the saturation start point in the saturated waveform. Also, the estimation unit 121 identifies a correction parameter based on the saturation width of the saturated waveform. Then, the estimator 121 estimates the peak position of the pulsed light by correcting the provisional peak position using the specified correction parameter. A detailed description is given below.
- the distance measuring device 10 further includes a light source 14 and a light receiving section 180 .
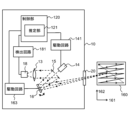
- FIG. 2 is a diagram illustrating in detail the configuration of the distance measuring device 10 according to this embodiment.
- dashed arrows schematically indicate paths of light.
- the configuration of the distance measuring device 10 will be described in detail with reference to this figure.
- Distance measuring device 10 measures the distance between distance measuring device 10 and an object (target object 30) within scanning range 160 based on, for example, the difference between the emission timing of pulsed light and the reception timing of reflected light (reflected pulsed light). It is a device for measuring distance.
- the object 30 is not particularly limited, and can be, for example, a living object, a non-living object, a mobile object, a stationary object, or the like.
- the pulsed light is light such as infrared light, for example. Also, the pulsed light is, for example, a laser pulse.
- the pulsed light emitted from the light source 14 provided in the distance measuring device 10 and emitted to the outside of the distance measuring device 10 through the transmission member 20 is reflected by an object and at least part of it is directed toward the distance measuring device 10. return. Then, the reflected light passes through the transmission member 20 again and enters the distance measuring device 10 .
- the reflected light incident on the distance measuring device 10 is received by the light receiving section 180 and its intensity is detected.
- the distance measuring device 10 measures the time from when the pulsed light is emitted from the light source 14 to when the reflected light is detected by the light receiving section 180 .
- the control unit 120 provided in the distance measuring device 10 calculates the distance between the distance measuring device 10 and the object using the measured time and the propagation speed of the pulsed light.
- the ranging device 10 is, for example, a lidar (LIDAR: Laser Imaging Detection and Ranging, Laser Illuminated Detection and Ranging or LiDAR: Light Detection and Ranging) device.
- the estimation unit 121 is included in the control unit 120 .
- the estimation unit 121 may be provided separately from the control unit 120 .
- the distance measuring device 10 When the distance measuring device 10 according to the present embodiment is attached to a mobile object such as a vehicle, the distance measurement result obtained by the distance measuring device 10 may be used for automatic driving or driving assistance of the mobile object.
- the light source 14 emits pulsed light.
- Light source 14 is, for example, a laser diode.
- Light receiving section 180 includes light receiving element 18 and detection circuit 181 .
- the light receiving element 18 receives the pulsed light incident on the distance measuring device 10 .
- Light receiving element 18 is, for example, a photodiode such as an avalanche photodiode (APD).
- APD avalanche photodiode
- the distance measuring device 10 further includes a movable mirror 16 .
- the movable mirror 16 is, for example, a uniaxially movable or biaxially movable MEMS mirror. By changing the orientation of the reflecting surface of the movable mirror 16, the emission direction of the pulsed light emitted from the distance measuring device 10 can be changed.
- the movable mirror 16 is a biaxially movable MEMS mirror, by biaxially driving the movable mirror 16, raster scanning can be performed within a predetermined range with pulsed light.
- the control unit 120 generates point cloud data including measurement results using a plurality of pulsed lights. For example, when raster scanning is performed within the scanning range 160 , linear scanning is performed by changing the light emission direction to the first direction 161 . By performing a plurality of linear scans while changing the light emitting direction in the second direction 162, point cloud data including a plurality of measurement results within the scanning range 160 can be generated.
- the first direction 161 and the second direction 162 are orthogonal.
- a unit of point cloud data generated by a single raster scan is called a frame. After the measurement of one frame is finished, the direction of light emission returns to the initial position, and the measurement of the next frame is performed. Thus, repeating frames are generated.
- distances measured by pulsed light are associated with information indicating the emission direction of the pulsed light.
- the point cloud data may include three-dimensional coordinates indicating reflection points of the pulsed light.
- the control unit 120 generates point cloud data using the calculated distance and information indicating the angle of the movable mirror 16 when emitting each pulsed light.
- the generated point cloud data may be output to the outside of the distance measuring device 10 or may be held in a storage device accessible from the control unit 120 .
- the distance measuring device 10 further includes a mirror 15 with a hole and a condenser lens 13 .
- the pulsed light emitted from the light source 14 passes through the hole of the mirror 15 with a hole, is reflected by the movable mirror 16 , and is emitted from the distance measuring device 10 .
- the reflected light incident on the distance measuring device 10 is reflected by the movable mirror 16 and the holed mirror 15 , and then enters the light receiving section 180 via the condenser lens 13 .
- the distance measuring device 10 may further include a collimating lens, a mirror, and the like.
- the control section 120 can control the light emitting section 140, the light receiving section 180, and the movable reflecting section 164 (see FIG. 3).
- Light emitting section 140 , light receiving section 180 and movable reflecting section 164 are included in distance measuring device 10 .
- Light emitting unit 140 includes light source 14 and drive circuit 141 .
- Light receiving section 180 includes light receiving element 18 and detection circuit 181 .
- Movable reflector 164 includes movable mirror 16 and drive circuit 163 .
- Drive circuit 141 is a circuit for causing light source 14 to emit light based on a control signal from control unit 120, and includes, for example, a switching circuit and a capacitive element.
- the detection circuit 181 includes an IV converter and an amplifier, and outputs a signal indicating the intensity of light detected by the light receiving element 18 .
- the control unit 120 and the estimating unit 121 acquire the light receiving signal from the light receiving unit 180 and detect the peak derived from the reflected light from the object 30 by performing processing for detecting the peak of the light receiving signal. Then, the control unit 120 calculates the distance from the distance measuring device 10 to the object 30 within the scanning range 160 as described above, using the light receiving timing (peak position) of the detected peak and the light emitting timing. calculate.
- the estimating unit 121 estimates the peak position based on the saturation waveform when the received light signal is saturated due to the pulsed received light. Then, the control unit 120 calculates the distance from the distance measuring device 10 to the object 30 using the peak position estimated by the estimation unit 121, that is, the light receiving timing of the reflected light.
- FIG. 3 is a diagram illustrating the hardware configuration of the distance measuring device 10 according to this embodiment.
- Control unit 120 and estimation unit 121 are implemented using integrated circuit 80 .
- the integrated circuit 80 is, for example, an SoC (System On Chip).
- the integrated circuit 80 has a bus 802 , a processor 804 , a memory 806 , a storage device 808 , an input/output interface 810 and a network interface 812 .
- a bus 802 is a data transmission path for the processor 804, memory 806, storage device 808, input/output interface 810, and network interface 812 to transmit and receive data to and from each other.
- the processor 804 is an arithmetic processing device implemented using a microprocessor or the like.
- a memory 806 is a memory implemented using a RAM (Random Access Memory) or the like.
- the storage device 808 is a storage device implemented using ROM (Read Only Memory), flash memory, or the like.
- the input/output interface 810 is an interface for connecting the integrated circuit 80 with peripheral devices.
- an input/output interface 810 is connected to a drive circuit 141 for the light source 14, a detection circuit 181 for the light receiving element 18, and a drive circuit 163 for the movable mirror 16.
- a network interface 812 is an interface for connecting the integrated circuit 80 to a communication network.
- This communication network is, for example, a CAN (Controller Area Network), Ethernet, LVDS (Low Voltage Differential Signaling), or the like.
- a method for connecting the network interface 812 to the communication network may be a wireless connection or a wired connection.
- the storage device 808 stores program modules for realizing the functions of the control unit 120 and the estimation unit 121 .
- the processor 804 implements the functions of the control unit 120 and the estimation unit 121 by reading this program module into the memory 806 and executing it.
- the hardware configuration of the integrated circuit 80 is not limited to the configuration shown in this figure.
- program modules may be stored in memory 806 .
- integrated circuit 80 may not include storage device 808 .
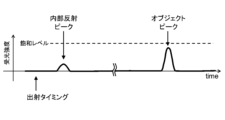
- FIG. 4 is a diagram showing an example of a light receiving signal generated by the light receiving section 180.
- FIG. This figure illustrates the received light signal from one pulsed light emission to the next pulsed light emission.
- the received light signal is a signal output from the detection circuit 181 and input to the control section 120 .
- the polarity of the received light signal with respect to the received light intensity is not limited to the example shown in this figure.
- the light receiving section 180 may have a configuration in which a larger light receiving signal is output in the negative direction as the intensity of light received by the light receiving element 18 increases.
- the saturation level of the light receiving section 180 is indicated by a dashed line.
- the saturation level of the light-receiving section 180 is the maximum signal level that can be output from the light-receiving section 180, and light intensity exceeding this level is not correctly reflected in the light-receiving signal.
- the light output from the light source 14 is emitted to the outside of the distance measuring device 10 mainly through the transmission member 20 as shown in FIG.
- at least part of the light output from the light source 14 is reflected inside the rangefinder 10 and becomes internally reflected light.
- the internally reflected light is received by the light receiving section 180 .
- This internally reflected light includes the light reflected by the transmissive member 20 .
- the transmission member 20 is a member that separates the inside and outside of the distance measuring device 10 and that transmits light.
- Transmissive member 20 is made of, for example, glass or resin.
- the light receiving section 180 receives internally reflected light and reflected light from the object 30 .
- FIG. 4 is a diagram illustrating the waveform of the light receiving signal of the light receiving section 180 when the light receiving section 180 does not saturate.
- the internally reflected light described above is received by the light receiving section 180 immediately after the light is emitted from the light source 14 .
- the reflected light from the object 30 is received by the light receiving section 180 at a timing corresponding to the distance from the distance measuring device 10 to the object 30 .
- the received light signal output from the light receiving unit 180 includes a peak due to the reception of internal reflected light (hereinafter also referred to as an “internal reflection peak”) and a peak from the object 30 .
- Peaks due to the reception of reflected light appear apart from each other. That is, in this case, it can be said that the first peak in the received light signal after the light is emitted is the internal reflection peak, and the second and subsequent peaks are the object peaks. However, the closer the object 30 is to the rangefinder 10, the closer these peaks are to each other.
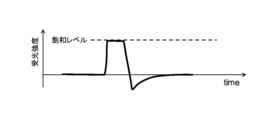
- FIG. 5 is a waveform illustrating saturated object peaks.
- the intensity of the reflected light from the object 30 is high, the peak intensity of the reflected light received from the object 30 exceeds the detection range of the light receiving unit 180, and the light receiving signal of the light receiving unit 180 is saturated as shown in this figure. There is Such saturation may occur, for example, when the object 30 is close to the rangefinder 10 or when the object 30 has a high light reflectance.
- the received light signal rises and saturates.
- the saturated state is released, the level returns to zero level (reference level), and the detection circuit 181 outputs a signal value of negative polarity.
- the light receiving signal is a signal that reflects the circuit characteristics of the light receiving element 18 and the detection circuit 181, and it is possible that a negative light receiving signal is output as shown in this figure due to the circuit characteristics. After taking the minimum value, the received light signal gradually returns to zero level.
- the peak width of the received light signal increases due to saturation.
- the signal until reaching the saturation state that is, the rising portion of the saturation waveform correctly reflects the received light intensity. Therefore, it can be said that the position of the saturation start point in the saturation waveform is well correlated with the actual peak position of the received light pulse, that is, the light receiving timing.
- the estimating unit 121 identifies the temporary peak position using a plurality of data points including the saturation start point in the saturated waveform. For example, the estimator 121 identifies the peak position of a Gaussian curve or quadratic curve passing through a plurality of data points as the temporary peak position. Then, the peak position of the pulsed light is estimated by correcting the provisional peak position using the correction parameter.
- the peak width of the received light signal increases due to saturation, and the increased peak width reflects the amount of charge accumulated in the light receiving section 180 . That is, the saturation width of the saturated waveform correlates with the amount of light received by the light receiving section 180 . Also, the larger the amount of light received by the pulsed light, the larger the difference between the temporary peak position and the actual peak position of the pulse. Therefore, the correction parameter can be specified based on the saturation width of the saturated waveform.
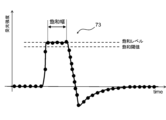
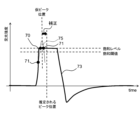
- FIG. 6 is a diagram illustrating the saturation width of the saturation waveform 73.
- the received light signal is composed of a plurality of time-series received light values sampled at predetermined intervals.
- the received light value indicates the received light intensity in the light receiving section 180 .
- the saturation width is, for example, the width (length of time) in which saturation occurs. For example, for a saturated waveform, a state in which the received light value exceeds a predetermined saturation threshold is defined as a state in which saturation occurs.
- the saturation threshold is a value slightly smaller than the saturation level of the light receiving section 180 .
- the estimating unit 121 determines the start point of saturation when the received light value exceeds a predetermined saturation threshold for the first time, and then identifies the last received light value exceeding the saturation threshold as the end point of saturation. Then, the estimation unit 121 sets the width from the saturation start point to the saturation end point as the saturation width of the saturated waveform. Note that the estimating unit 121 may count the number of received light values exceeding the saturation threshold for a certain saturated waveform, and set the saturation width to a value obtained by multiplying the counted number by a predetermined time.
- the estimation unit 121 can identify the correction parameter using the identified saturation width and reference information.
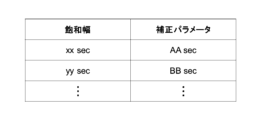
- the reference information is information in which a correction parameter is associated with each of a plurality of saturation widths. Specifically, in the reference information, a larger saturation width is associated with a larger correction parameter.
- the reference information may be a table, or may be a mathematical expression that allows calculation of the correction parameter from the saturation width. Also, in the reference information, the saturation width range and the correction parameter may be associated.
- the reference information is held in advance in a storage unit (for example, storage device 808) accessible from the estimation unit 121. FIG.
- the reference information can be created based on experimental measurement results in advance and stored in the storage unit. For example, a first light receiving section having the same conditions as the light receiving section 180 of the distance measuring device 10 and a second light receiving section having a larger detection range than the first light receiving section are prepared. Then, the same pulsed light is made incident on the first light receiving section and the second light receiving section to obtain the received light waveform by each light receiving section. At this time, a pulsed light beam having such an intensity as to obtain a saturated waveform only at the first light receiving portion is made incident. Then, for the saturated waveform obtained by the first light receiving section, the provisional peak position and saturation width are specified by the processing performed by the estimating section 121 .
- the peak position of the non-saturated light receiving waveform obtained by the second light receiving section is specified.
- the difference between the provisional peak position and the correct peak position is used as a correction parameter and associated with the specified saturation width.
- Such association is performed using a plurality of pulsed lights with different intensities, and a correction parameter is associated with each of the plurality of saturation widths.
- the reference information is a formula
- the reference information may be obtained by fitting the obtained relationship between the correction parameter and the saturation width.
- FIG. 7 is a diagram showing an example of reference information.
- the reference information is a table, and a correction parameter is associated with each of a plurality of saturation widths.
- the estimating unit 121 reads the reference information from the storage unit, and specifies the correction parameter associated with the specified saturation width in the reference information as the correction parameter to be used for correction. For example, when the reference information is a table, estimation section 121 identifies a correction parameter corresponding to the identified saturation width. When the range of saturation width and the correction parameter are associated with the reference information, the estimation unit 121 identifies the range to which the identified saturation width belongs, and identifies the correction parameter corresponding to the range. When the reference information is a formula, the estimation unit 121 substitutes the specified saturation width into the formula to obtain a correction parameter.
- FIG. 8 is a diagram showing another example of reference information.
- the estimator 121 may specify the correction parameter further based on the configuration of the optical system of the distance measuring device 10 . That is, as in the example of this figure, in the reference information, a correction parameter may be associated with each of a plurality of combinations of the configuration of the optical system and the saturation width.
- the reference information is a formula
- the formula is provided for each configuration of the optical system.
- the saturated waveform can vary depending on the configuration of the optical system, for example, whether or not a telephoto lens is provided in the portion of the distance measuring device 10 from which the pulsed light is incident. Therefore, by using a correction parameter determined for each configuration of the optical system, it is possible to improve the estimation accuracy of the peak position.
- the reference information in this example can also be generated by performing measurements in advance under the conditions of each configuration of the optical system.
- Information indicating the configuration of the optical system is previously input by the user to the distance measuring device 10, for example.
- the estimating unit 121 can acquire information indicating the configuration of the optical system input to the distance measuring device 10 and use it to specify correction parameters.
- the distance measurement method according to the present embodiment is a distance measurement method in which pulsed light emitted from the light source 14 and reflected by the object 30 is detected by the light receiving unit 180 .
- This ranging method includes an estimation step of estimating the peak position of the pulsed light.
- the peak position of the pulsed light is estimated using a saturated waveform, which is a received light waveform in which the received light signal is partially saturated, generated by the light receiving unit 180 that received the pulsed light.
- a provisional peak position is specified using a plurality of data points including a saturation start point in the saturated waveform, and a correction parameter is specified based on the saturation width of the saturated waveform. Then, by correcting the provisional peak position using the identified correction parameter, the peak position of the pulsed light is estimated.
- FIG. 9 is a flowchart illustrating the flow of processing performed by the estimation unit 121 according to this embodiment.
- FIG. 10 is a diagram for explaining the processing performed by the estimation unit 121 according to this embodiment.
- FIG. 10 shows the process of processing using the saturated waveform 73.
- the estimating section 121 acquires a received light signal from the light receiving section 180 (S11).
- the estimation unit 121 may acquire the received light signal from the light receiving unit 180 or may acquire it from another part of the control unit 120 .
- the estimation unit 121 may read and acquire information indicating the received light signal, which is temporarily held in the storage unit.
- the estimating unit 121 acquires a received light signal each time pulsed light is emitted from the light source 14, for example.
- the estimating unit 121 treats, for example, the received light signal from the emission of a certain pulsed light to the emission of the next pulsed light as one unit, and performs the series of processing in FIG. 9 for each unit.
- the estimating unit 121 determines whether or not the received light waveform due to pulsed light reception is saturated in the received light signal (S12). Specifically, when the received light value in the received light signal exceeds a predetermined saturation threshold, the estimating unit 121 determines that the received light waveform due to pulsed received light is saturated (Yes in S12). On the other hand, if it is not determined that the received light waveform is saturated (No in S12), the estimation unit 121 performs normal peak detection processing using the received light signal, and identifies the peak position of the object peak that is not saturated. (S18). Determining the peak positions of non-saturated object peaks can be done using existing techniques. Then, the estimating unit 121 terminates the processing for the pulsed light emission. Note that the peak position of the peak that is not saturated may be specified by the control unit 120 instead of the estimation unit 121 .
- the estimating unit 121 identifies the starting point of saturation (S13). Specifically, the estimating unit 121 sets the point (light receiving value) at which the light receiving value exceeds the saturation threshold for the first time in the acquired light receiving signal as the saturation start point 70 . Next, the estimation unit 121 identifies a plurality of edge sample points including the saturation start point 70 (S14). In the example of FIG. 10, points (light receiving values) 71 before and after the starting point 70 and the starting point 70 are combined to form a plurality of edge sample points. That is, in this example, the estimation unit 121 identifies three edge sample points. However, the estimation unit 121 may specify four or more edge sample points. The plurality of edge sample points preferably includes one or more points before and one or more points after the saturation start point 70 .
- the estimating unit 121 then identifies a curve 75 passing through a plurality of edge sample points (S15). As described above, the estimation unit 121 identifies, for example, a Gaussian curve or a quadratic curve passing through a plurality of edge sample points. A curve passing through a plurality of edge sample points can be identified using existing fitting processing techniques or the like. Then, the estimating unit 121 identifies the identified peak position of the curve 75 as a provisional peak position (S16).
- the estimation unit 121 identifies the saturation width of the saturated waveform 73 by the method described above, and further identifies the correction parameter using the saturation width. Then, the peak position is estimated by correcting the provisional peak position using the specified correction parameter (S17). Specifically, the estimator 121 sets the position obtained by shifting the temporary peak position by the correction parameter as the estimated peak position. For example, the estimated peak position (time from the emission timing) is later (longer time) than the tentative peak position. That is, the estimation unit 121 obtains the estimated peak position by adding the correction parameter to the temporary peak position. Alternatively, the estimation unit 121 may calculate an estimated peak position by performing a calculation using a correction parameter on the temporary peak position. After obtaining the estimated peak position, the estimator 121 terminates the processing for the pulsed light emission. The estimator 121 performs these processes each time pulsed light is emitted.
- the control unit 120 calculates the distance from the distance measuring device 10 to the target object 30 using the specified peak positions, that is, the peak positions specified in S18 and the peak positions estimated in S17.
- the estimating unit 121 may specify the provisional peak position using a plurality of data points including the saturation end point instead of specifying the provisional peak position using the plurality of data points including the saturation start point. good.
- the onset of saturation reflects the position of the saturating peak component more accurately than the end of saturation, so multiple data points including the onset of saturation should be used. is preferred.
- the estimation unit 121 identifies the provisional peak position using a plurality of data points including the saturation start point in the saturated waveform. Also, the estimation unit 121 identifies a correction parameter based on the saturation width of the saturated waveform. Then, the estimator 121 estimates the peak position of the pulsed light by correcting the provisional peak position using the specified correction parameter. Therefore, the peak position of the saturated received light waveform can be estimated with a small processing load.
- the estimating unit 121 specifies the correction parameter based on whether the saturated waveform is the first pulse received by the light receiving unit 180 after the pulsed light is emitted. It is the same as the distance measuring device 10 according to the first embodiment except that A detailed description is given below.
- FIG. 11 is a diagram illustrating a received light signal when the object 30 exists at a close distance from the distance measuring device 10.
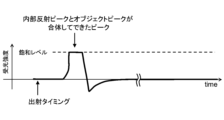
- the reflected light has a high intensity and the light receiving section 180 is saturated. Further, since the distance measuring device 10 and the object 30 are close to each other, the reflected light from the object 30 is received immediately after the light is emitted from the distance measuring device 10 . As a result, a saturated peak, which is the sum of the saturated object peak and the internally reflected light peak, appears in the received light signal.
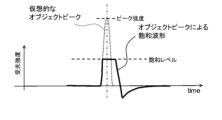
- FIG. 12 is a diagram illustrating the waveform of a single saturated object peak
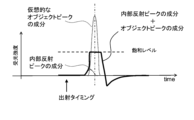
- FIG. 13 is a diagram showing the combination of the saturated object peak and the internal reflection peak due to the presence of the object 30 in the close range of the rangefinder 10.
- FIG. 11 is a diagram illustrating waveforms in a case; Each saturation waveform will be described with reference to FIGS. 12 and 13 .
- a virtual object peak is indicated by a dashed line superimposed on the saturated waveform.
- the virtual object peak is a waveform assumed based on the received light intensity at the light receiving unit 180 when it is assumed that the light receiving unit 180 is not saturated.
- a saturated waveform is output as an actual received light signal.
- Such a saturated waveform due to a single object peak can appear after the second peak after the pulse is emitted from the light source 14 and the internally reflected light is received.
- the rising portion of such a saturated waveform well reflects the initial shape and position of the rising of the virtual object peak.
- the internal reflection peak component and the virtual object peak component due to reflected light from the object 30 at a close distance from the distance measuring device 10 are indicated by dashed lines. Comparing the internal reflection peak component and the virtual object peak component, the peak position is shifted. Specifically, the peak position of the internal reflection peak component is before the peak position of the virtual object peak component (that is, close to the emission timing of the pulsed light). This is because the reflected light from the object 30 takes slightly longer time to be received than the internally reflected light. In an actual received light signal, a saturated waveform is output as a result of adding the internal reflection peak component and the object peak component.
- a saturated waveform resulting from the combination of the saturated object peak and the internal reflection peak can appear as the first peak after the pulse is emitted from the light source 14 .
- the shape of the rising portion of the saturated waveform is influenced by both the internal reflection peak component and the virtual object peak component.
- the estimating section 121 determines that the saturated waveform is the first pulse received by the light receiving section 180 after the pulsed light is emitted (hereinafter referred to as "first pulse received"). A correction parameter is specified further based on whether or not. By doing so, it is possible to improve the estimation accuracy of the peak position.
- FIG. 14 is a diagram illustrating reference information according to this embodiment.
- a correction parameter is associated with each of a plurality of combinations of whether the saturated waveform is due to the first pulse light reception and the saturation width.
- the reference information in this example can also be generated by performing experimental measurements in advance under conditions that cause reflection from an object at a close distance, as in the example of the first embodiment.
- correction parameters are provided for each of a plurality of combinations of whether or not the saturated waveform is due to the first pulse light reception, the configuration of the optical system, and the saturation width. It may be related.
- the reference information when the reference information is a formula, the reference information includes a formula to be used when the saturated waveform is due to the first pulsed light reception and a formula to be used when the saturated waveform is not due to the first pulsed light reception. be If the saturation width is the same, the correction parameter when the saturated waveform is due to the first pulsed light reception is set larger than the correction parameter when the saturated waveform is not due to the first pulsed light reception.
- the estimation unit 121 uses the acquired received light signal. It is determined whether or not the saturated waveform is due to the first pulse light reception. Specifically, when the light receiving value exceeding the predetermined noise threshold continues for the first time or more after the pulsed light is emitted, the estimating unit 121 determines that the light receiving value exceeding the noise threshold is due to the first pulse light receiving. It is determined that it constitutes a peak. Note that the noise threshold can be set to a value slightly larger than the noise level of the received light signal. If the received light value determined to exceed the saturation threshold in S12 is included in the received light value forming the peak due to the first pulse received light, the estimator 121 determines that the saturated waveform is due to the first pulse received light.
- the estimation unit 121 uses the determination result to specify the correction parameter. For example, the estimating unit 121 identifies, in the reference information, a correction parameter corresponding to a combination of the determination result for the target saturated waveform and the saturation width as the correction parameter to be used for correcting the temporary peak position. Then, using the specified correction parameter, the temporary peak position is corrected in the same manner as in the first embodiment, and an estimated peak position is obtained.
- the estimator 121 identifies the correction parameter based on whether the saturated waveform is due to the first pulse light reception in the light receiver 180 after the pulse light is emitted. Therefore, the peak position can be estimated with higher accuracy.
- the distance measuring device 10 estimates the peak intensity of the received pulsed light based on the saturation width of the saturated waveform, and uses the estimated peak intensity and the estimated peak position to measure the reflection of the target object 30. It is the same as the distance measuring device 10 according to at least one of the first and second embodiments except that at least one of intensity and reflectance is estimated. A detailed description is given below.
- the distance measuring device 10 has a function of calculating and outputting the reflectance of the object 30 based on the light reception result for each emitted pulse.
- the distance measuring device 10 may output information indicating the reflection intensity of the object 30 based on the received light result for each emitted pulse.
- the information output from the ranging device 10 may be used for automatic driving or driving assistance of the moving body.
- the reflectance of the object 30 can be calculated using the reflection intensity of the object 30 and the distance from the rangefinder 10 to the object 30 .
- the reflected intensity can usually be specified using the peak intensity in the received light signal, but when the object peak is saturated, the peak intensity cannot be read directly from the received light signal.
- the estimator 121 estimates the peak intensity of the pulsed light using the saturation width of the saturated waveform. Specifically, the estimation unit 121 estimates the peak intensity of the pulsed light using the saturation width and the intensity reference information. Since there is a correlation between saturation width and peak intensity, peak intensity can be estimated in this manner.
- the intensity reference information is information in which an estimated peak intensity is associated with each of multiple saturation widths. Specifically, in the intensity reference information, a larger saturation width is associated with a larger estimated peak intensity.
- the intensity reference information may be a table, or may be a formula that can calculate the estimated peak intensity from the saturation width. Also, in the intensity reference information, the saturation width range and the estimated peak intensity may be associated.
- the intensity reference information is held in advance in a storage unit (for example, storage device 808) accessible from the estimation unit 121. FIG.
- Intensity reference information can be created based on preliminary experimental measurement results and stored in the storage unit. For example, a first light receiving section having the same conditions as the light receiving section 180 of the distance measuring device 10 and a second light receiving section having a larger detection range than the first light receiving section are prepared. Then, the same pulsed light is made incident on the first light receiving section and the second light receiving section to obtain the received light waveform by each light receiving section. At this time, a pulsed light beam having such an intensity as to obtain a saturated waveform only at the first light receiving portion is made incident. Then, the saturation width is specified by the processing performed by the estimating unit 121 for the saturated waveform obtained by the first light receiving unit.
- the peak intensity of the non-saturated received light waveform obtained by the second light receiving section is specified. Then, the identified peak intensity and saturation width are associated. Such association is performed using a plurality of pulsed lights, and the peak intensity is associated with each of a plurality of saturation widths.
- the intensity reference information is a formula
- the intensity reference information may be obtained by fitting the obtained relationship between the peak intensity and the saturation width.
- the estimating unit 121 detects the saturated waveform in the received light signal and specifies the saturation width of the saturated waveform using the same method as described above in the first embodiment. Then, as described above, the peak intensity is estimated using the saturation width and the intensity reference information. The estimating unit 121 further calculates the reflectance of the object 30 using the estimated peak intensity and the distance to the object 30 calculated using the estimated peak position of the saturated waveform. good. An existing method can be used to calculate the reflectance.
- control unit 120 can specify the peak intensity by an existing method and calculate at least one of the reflection intensity and the reflectance.
- the range finder 10 estimates the peak intensity of the pulsed light based on the saturation width of the saturated waveform, and uses the estimated peak intensity and the estimated peak position to measure the reflection of the object 30. Estimate at least one of intensity and reflectance. Therefore, more information about the object 30 is obtained.
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Computer Networks & Wireless Communication (AREA)
- General Physics & Mathematics (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Electromagnetism (AREA)
- Optical Radar Systems And Details Thereof (AREA)
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023569435A JP7602066B2 (ja) | 2021-12-23 | 2022-12-19 | 測距装置および測距方法 |
| US18/717,737 US20250052898A1 (en) | 2021-12-23 | 2022-12-19 | Distance measurement apparatus and distance measurement method |
| CN202280083940.4A CN118435078A (zh) | 2021-12-23 | 2022-12-19 | 测距装置及测距方法 |
| EP22911181.0A EP4455722A4 (en) | 2021-12-23 | 2022-12-19 | DISTANCE MEASURING DEVICE AND DISTANCE MEASURING METHOD |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-209383 | 2021-12-23 | ||
| JP2021209383 | 2021-12-23 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023120479A1 true WO2023120479A1 (ja) | 2023-06-29 |
Family
ID=86902458
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/046682 Ceased WO2023120479A1 (ja) | 2021-12-23 | 2022-12-19 | 測距装置および測距方法 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US20250052898A1 (cg-RX-API-DMAC7.html) |
| EP (1) | EP4455722A4 (cg-RX-API-DMAC7.html) |
| JP (1) | JP7602066B2 (cg-RX-API-DMAC7.html) |
| CN (1) | CN118435078A (cg-RX-API-DMAC7.html) |
| WO (1) | WO2023120479A1 (cg-RX-API-DMAC7.html) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP4790453A1 (de) * | 2025-02-07 | 2026-08-12 | Sick Ag | Verfahren zum betreiben eines optischen laufzeitsensors, optischer laufzeitsensor und computerprogrammprodukt |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002022831A (ja) | 2000-07-10 | 2002-01-23 | Denso Corp | 物体認識方法及び装置、記録媒体 |
| JP2021518549A (ja) * | 2018-03-20 | 2021-08-02 | パノセンス インコーポレイテッド | パルスタイプに応じたlidarパルスディテクタの選択 |
| JP2021139625A (ja) * | 2020-03-02 | 2021-09-16 | 三菱電機株式会社 | 物体検知装置 |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US7501621B2 (en) * | 2006-07-12 | 2009-03-10 | Leco Corporation | Data acquisition system for a spectrometer using an adaptive threshold |
| AU2014352833B2 (en) * | 2013-11-22 | 2019-12-05 | Aurora Operations, Inc. | LiDAR scanner calibration |
| US11105925B2 (en) * | 2017-03-01 | 2021-08-31 | Ouster, Inc. | Accurate photo detector measurements for LIDAR |
| JP6877845B2 (ja) * | 2017-09-22 | 2021-05-26 | 株式会社トプコン | レーザスキャナの測定値補正方法およびそのための装置 |
| US10768281B2 (en) * | 2018-03-20 | 2020-09-08 | Panosense Inc. | Detecting a laser pulse edge for real time detection |
| WO2020201452A1 (en) * | 2019-04-02 | 2020-10-08 | Ams International Ag | Method of measuring optical crosstalk in a time of flight sensor and corresponding time of flight sensor |
| US20220035035A1 (en) * | 2020-07-31 | 2022-02-03 | Beijing Voyager Technology Co., Ltd. | Low cost range estimation techniques for saturation in lidar |
-
2022
- 2022-12-19 WO PCT/JP2022/046682 patent/WO2023120479A1/ja not_active Ceased
- 2022-12-19 CN CN202280083940.4A patent/CN118435078A/zh active Pending
- 2022-12-19 US US18/717,737 patent/US20250052898A1/en active Pending
- 2022-12-19 JP JP2023569435A patent/JP7602066B2/ja active Active
- 2022-12-19 EP EP22911181.0A patent/EP4455722A4/en active Pending
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002022831A (ja) | 2000-07-10 | 2002-01-23 | Denso Corp | 物体認識方法及び装置、記録媒体 |
| JP2021518549A (ja) * | 2018-03-20 | 2021-08-02 | パノセンス インコーポレイテッド | パルスタイプに応じたlidarパルスディテクタの選択 |
| JP2021139625A (ja) * | 2020-03-02 | 2021-09-16 | 三菱電機株式会社 | 物体検知装置 |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4455722A4 |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2023120479A1 (cg-RX-API-DMAC7.html) | 2023-06-29 |
| CN118435078A (zh) | 2024-08-02 |
| EP4455722A4 (en) | 2025-12-17 |
| JP7602066B2 (ja) | 2024-12-17 |
| EP4455722A1 (en) | 2024-10-30 |
| US20250052898A1 (en) | 2025-02-13 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111868561B (zh) | 使用本底噪声的自适应识别进行有效信号检测 | |
| US20210239806A1 (en) | Selecting lidar pulse detector depending on pulse type | |
| US10768281B2 (en) | Detecting a laser pulse edge for real time detection | |
| KR100770805B1 (ko) | 3차원 거리측정 이미지를 기록하기 위한 방법 및 장치 | |
| EP3457177A1 (en) | Distance measurement apparatus | |
| JP7468999B2 (ja) | マルチパス検出装置およびマルチパス検出方法 | |
| WO2020191727A1 (zh) | 一种雷达功率控制方法及装置 | |
| JP2006322834A (ja) | 距離測定装置、及び距離測定方法 | |
| WO2017221909A1 (ja) | 距離測定装置 | |
| US20170328991A1 (en) | Distance measuring device and method for determining a distance | |
| JP7602066B2 (ja) | 測距装置および測距方法 | |
| CN110346813B (zh) | 脉冲光检测和测距装置、在脉冲光检测和测距系统中对物体进行检测和测距的系统和方法 | |
| JP2021139625A (ja) | 物体検知装置 | |
| WO2020172892A1 (zh) | 一种雷达功率控制方法和装置 | |
| JP6733495B2 (ja) | 距離測定装置 | |
| JP2020148747A (ja) | 物体検出装置 | |
| KR101805253B1 (ko) | 물체 인식 장치 및 그를 이용한 물체 인식 방법 | |
| KR101559458B1 (ko) | 물체 인식 장치 및 그를 이용한 물체 인식 방법 | |
| JP7642866B2 (ja) | 測距装置、判定装置、判定方法、およびプログラム | |
| JPH06109842A (ja) | 距離検出装置 | |
| US12429594B2 (en) | Time-of-flight sensing using continuous wave and coded modulation measurements | |
| JP7588489B2 (ja) | 物体の反射率に依存しない飛行時間 | |
| WO2023090415A1 (ja) | 測距装置 | |
| JP7611422B2 (ja) | 測距装置、モデル生成装置、情報生成装置、情報生成方法、およびプログラム | |
| US10241204B2 (en) | Method for illuminating an object |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22911181 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023569435 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 18717737 Country of ref document: US |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202280083940.4 Country of ref document: CN |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 2022911181 Country of ref document: EP Effective date: 20240723 |