WO2022145104A1 - 液圧式手術用器具 - Google Patents
液圧式手術用器具 Download PDFInfo
- Publication number
- WO2022145104A1 WO2022145104A1 PCT/JP2021/037840 JP2021037840W WO2022145104A1 WO 2022145104 A1 WO2022145104 A1 WO 2022145104A1 JP 2021037840 W JP2021037840 W JP 2021037840W WO 2022145104 A1 WO2022145104 A1 WO 2022145104A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- supply
- relief valve
- pressure chamber
- path
- discharge
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
Definitions
- the present invention relates to a hydraulic surgical instrument.
- a hydraulic surgical instrument that operates a pair of jaws constituting a gripper or the like by hydraulic pressure has been known.
- a cylinder-type hydraulic actuator that opens and closes a pair of jaws (referred to as “biopsy jaw portion” in Patent Document 1) and a hydraulic fluid are supplied and discharged to the hydraulic actuator.
- An endoscopic device including a feeding / discharging device is described.
- the hydraulic actuator is the first cylinder, and the inside of the first cylinder is divided into a first pressure chamber and a second pressure chamber. Includes piston.
- the first piston is connected to a pair of jaws via an opening / closing mechanism.
- the supply / discharge device includes a second cylinder and a second piston that divides the inside of the second cylinder into a first operating chamber and a second operating chamber.
- the first operating chamber is connected to the first pressure chamber by the first supply / exhaust passage
- the second operating chamber is connected to the second pressure chamber by the second supply / exhaust passage.
- the pressure in the first supply / discharge passage or the second supply / discharge passage may become too high when the jaw is closed or opened. If the pressure in the first supply / discharge passage or the second supply / discharge passage becomes too high, a malfunction may occur in the jaw, the hydraulic pressure device, or the like.
- an object of the present invention is to provide a hydraulic surgical instrument capable of preventing the pressure of the first supply / exhaust passage or the second supply / exhaust passage from becoming too high.
- the hydraulic surgical instrument of the present invention has a hydraulic actuator including a first pressure chamber and a second pressure chamber that opens and closes at least one jaw, a cylinder, and the inside of the cylinder.
- a supply / discharge device including a piston that partitions the first operating chamber and the second operating chamber, a first supply / discharge passage that connects the first operating chamber to the first pressure chamber, and the second operating chamber to the second pressure.
- a second supply / discharge passage connecting to the chamber, a relief valve, an inflow passage connecting the inflow port of the relief valve to one of the first supply / discharge passage and the second supply / discharge passage, and an outflow port of the relief valve. Is provided with an outflow path connecting the first supply / discharge path and the other of the second supply / discharge path.
- the relief valve opens when the pressure of the supply / discharge passage exceeds the set pressure of the relief valve while the inflow passage of the first supply / discharge passage and the second supply / discharge passage is connected.
- the hydraulic fluid flows from one supply / discharge passage to the other supply / discharge passage via the inflow passage, the relief valve and the outflow passage. Therefore, it is possible to prevent the pressure of the supply / discharge passage, which is the first supply / discharge passage or the second supply / discharge passage, from becoming too high.
- a hydraulic surgical instrument capable of preventing the pressure of the first supply / discharge passage or the second supply / discharge passage from becoming too high.
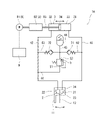
- FIG. 1 shows a hydraulic surgical instrument 1A according to the first embodiment of the present invention.
- the surgical instrument 1A includes a pair of jaws 11 and 12 constituting a gripper or the like.
- the jaws 11 and 12 may be those that sandwich the affected area or those that crush the clips used in surgery.
- the jaw 11 is fixed and the jaw 12 opens and closes.
- the surgical instrument 1A includes a hydraulic actuator 2 that opens and closes the jaw 12, and a supply / discharge device 3 that supplies / discharges the hydraulic fluid to the hydraulic actuator 2. Further, the surgical instrument 1A includes a drive device 8 for driving the supply / discharge device 3 and a control device 9 for controlling the drive device 8.
- the hydraulic fluid used in the surgical instrument 1A is not particularly limited, but is, for example, physiological saline or oil.
- the surgical instrument 1A includes a drive unit and an insertion tube extending from the drive unit and inserted into the patient's body.
- the supply / discharge device 3 and the drive device 8 are provided in the drive unit, and the hydraulic actuator 2 and the jaws 11 and 12 are provided at the tip of the insertion tube.
- a relief valve 5, check valves 71, 72 and a tank 44, which will be described later, are also provided in the drive unit.
- the drive unit is attached to the surgical robot.
- the linear motion mechanism 82 described later of the drive device 8 may be provided in the drive unit, and the electric motor 81 described later of the drive device 8 may be provided in the surgical robot.
- the hydraulic actuator 2 includes a first pressure chamber 21 for closing the jaw 12 and a second pressure chamber 22 for opening the jaw 12.
- the hydraulic actuator 2 is a vane type, and the first pressure chamber 21 and the second pressure chamber 22 are separated by a swinging vane 23.
- the vane 23 is arranged in the hollow housing 24.
- the jaw 11 described above is fixed to the housing 24.
- the vane 23 is fixed to the swing shaft shown in the figure, and the swing shaft is rotatably supported by the housing 24. At least one end of the swing shaft is located outside the housing 24, and the jaw 12 is fixed to this one end. That is, the jaw 12 swings with the vane 23.
- the housing 24 has a fan-shaped or semicircular internal space when viewed from the axial direction of the swing shaft, and this internal space is divided into a first pressure chamber 21 and a second pressure chamber 22 by a vane 23.
- the center angle thereof may be substantially the same as the opening / closing angle of the jaw 12 (the swing angle of the vane 23).
- the vane 23 may abut on one wall surface of the internal space when the jaw 12 is fully opened.
- one wall surface of the internal space may function as an open side stopper of the vane 23.
- a stopper that comes into contact with the vane 23 when the jaw 12 is fully opened may be provided in the first pressure chamber 21.
- the supply / discharge device 3 includes a cylinder 33 and a piston 34 that partitions the inside of the cylinder 33 into a first operating chamber 31 and a second operating chamber 32.
- the cylinder 33 includes a tube that slidably holds the piston 34 and a pair of end plates that block both ends of the tube.
- the first operating chamber 31 is connected to the first pressure chamber 21 by the first supply / discharge passage 41, and the second operating chamber 32 is connected to the second pressure chamber 22 by the second supply / discharge passage 42.
- the surgical instrument 1A includes a relief valve 5 having an inflow port 51 and an outflow port 52.
- the inflow port 51 is connected to the second supply / discharge passage 42 by the open side inflow passage 61
- the outflow port 52 is connected to the first supply / discharge passage 41 by the open side outflow passage 62.
- the outflow port 52 of the relief valve 5 is connected to the tank 44 by the tank path 43.
- the portion of the tank passage 43 on the relief valve 5 side merges with the portion on the upstream side of the open side outflow passage 62 to form a common flow path.
- the tank 44 stores the hydraulic fluid flowing out of the relief valve 5 in a pressurized state.
- the pressure of the hydraulic fluid in the tank 7 is 0.2 to 0.3 MPa.
- the branch road 63 branches from the tank road 43, and this branch road 63 is connected to the second supply / discharge road 42. Therefore, check valves 71 and 72 are provided in the open side outflow passage 62 and the branch passage 63, respectively.
- the check valve 71 allows the flow from the relief valve 5 to the first supply / discharge passage 41, but prohibits the reverse flow
- the check valve 72 allows the flow from the tank passage 43 to the second supply / discharge passage 42. However, the reverse flow is prohibited.
- the pressure of the hydraulic fluid in the tank 44 is sufficiently higher than the cracking pressure of the check valves 71 and 72.
- the drive device 8 described above moves the piston 34 of the supply / discharge device 3 in the closing direction from the second operating chamber 32 toward the first operating chamber 31 and in the opening direction from the first operating chamber 31 toward the second operating chamber 32.
- the drive device 8 includes an electric motor 81 and a linear motion mechanism 82 that converts the rotational motion of the electric motor 81 into a linear motion of the piston 34.
- the configuration of the drive device 8 is not limited to this, and can be changed as appropriate.
- the linear motion mechanism 82 has a rod 83 to which the piston 34 is fixed.
- the rod 83 penetrates only the end plate of the cylinder 33 on the linear motion mechanism 82 side.
- the rod 83 may penetrate both end plates of the cylinder 33.
- the linear motion mechanism 82 may have a screw shaft and a nut member screwed to the screw shaft, or may have a rack and a pinion that mesh with each other.
- the control device 9 described above controls the electric motor 81 of the drive device 8.
- An open command and a close command for the jaw 12 are input to the control device 9.
- the control device 9 is a computer having a memory such as a ROM or a RAM, a storage such as an HDD or an SSD, and a CPU, and the program stored in the ROM or the storage is executed by the CPU.
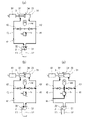
- the control device 9 controls the electric motor 81 so that the piston 34 moves in the closing direction as shown in FIG. 2A.
- the hydraulic fluid is supplied from the first operating chamber 31 to the first pressure chamber 21 through the first supply / discharge passage 41, and at the same time, the hydraulic fluid is operated from the second pressure chamber 22 to the second operating chamber 32 through the second supply / discharge passage 42.
- the liquid is drained.
- the jaw 12 closes in synchronization with the movement of the piston 34.
- the volume of the portion of the rod 83 that newly enters the second operating chamber 32 is the volume of the first operating chamber 31.
- the total volume of the first supply / discharge passage 41, the first pressure chamber 21, the second pressure chamber 22, the second supply / discharge passage 42, and the second operating chamber 32 is reduced. Further, the outflow rate Q1 of the hydraulic fluid from the first operating chamber 31 is larger than the inflow rate Q2 of the hydraulic fluid into the second operating chamber 32.
- the first pressure chamber is held until the jaw 12 reaches the end of the movable range.
- the pressures of the 21 and the second pressure chamber 22 both rise equally, the inflow / outflow flow rate Q3 of the hydraulic actuator 2 is smaller than the outflow flow rate Q1 of the hydraulic fluid from the first working chamber 31, and the flow to the second working chamber 32.
- the vane 23 moves so as to be larger than the inflow flow rate Q2 of the hydraulic fluid.
- the difference between Q1 and Q3 is absorbed by the volume change of the hydraulic fluid in the first supply / discharge passage 41, and the difference between Q3 and Q2 is absorbed by the volume change of the hydraulic fluid in the second supply / discharge passage 42.
- the pressure of the second pressure chamber 22 is higher than that of the first pressure chamber 21 by the pressure corresponding to the force corresponding to the reaction force received by the jaw 12 and the frictional force of the moving part and the hydraulic fluid minus the inertial force.
- the pressures of the second pressure chamber 22 and the first pressure chamber 21 both increase while maintaining the difference.
- the pressure in the second pressure chamber 22 decreases as the piston 34 moves, and the first pressure chamber 21 and the second pressure chamber 21 A higher differential pressure is generated between the pressure chamber 21 and the pressure chamber 21, and the jaw 12 exerts a gripping force.
- the differential pressure between the first pressure chamber 21 and the second pressure chamber 22 becomes large, an internal leak occurs in the hydraulic actuator 2 as shown by an arrow in FIG. 2A.
- the control device 9 controls to prevent the pressure of the first supply / discharge passage 41 from becoming too high when the jaw 12 is closed. Specifically, when the jaw 12 is closed, the control device 9 keeps the current supplied to the electric motor 81 at the upper limit when the current reaches the upper limit. As a result, it is possible to prevent the pressure of the first supply / discharge passage 41 from becoming too high when the jaw 12 is closed.
- control device 9 controls the electric motor 81 so that the piston 34 moves in the open direction as shown in FIG. 2 (b).
- the hydraulic fluid is supplied from the second operating chamber 32 to the second pressure chamber 22 through the second supply / discharge passage 42, and the hydraulic fluid is operated from the first pressure chamber 21 to the first operating chamber 31 through the first supply / discharge passage 41.
- the liquid is drained.
- the jaw 12 opens in synchronization with the movement of the piston 34.
- the inflow rate Q1 of the hydraulic fluid into the first operating chamber 31 is larger than the outflow flow rate Q2 of the hydraulic fluid from the second operating chamber 32. big.
- the shortage of hydraulic fluid which is the difference between the inflow flow rate Q1 and the outflow flow rate Q2, is supplied from the tank 44 to the first supply / discharge passage 41 through the tank passage 43 and the open side outflow passage 62.
- the pressure of the second supply / discharge passage 42 becomes the set pressure of the relief valve 5 (as shown in FIG. 2C).
- the relief valve 5 opens, and the second supply / discharge passage 42 goes to the first supply / discharge passage 41 via the open side inflow passage 61, the relief valve 5, and the open side outflow passage 62.
- the hydraulic fluid flows in.
- the tank 44 for storing the hydraulic fluid flowing out from the relief valve 5 in a pressurized state since the tank 44 for storing the hydraulic fluid flowing out from the relief valve 5 in a pressurized state is provided, the pressure on the downstream side of the relief valve 5 can be kept high to some extent. This makes it possible to promote the inflow of the hydraulic fluid into the first operating chamber 31 when the relief valve 5 is opened.
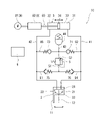
- FIG. 3 shows a hydraulic surgical instrument 1B according to a second embodiment of the present invention.
- the same components as those in the first embodiment are designated by the same reference numerals, and duplicate description will be omitted.
- the inflow port 51 of the relief valve 5 is connected to the first supply / discharge passage 41 by the closed side inflow passage 64, and the outflow port 52 is connected to the second supply / discharge passage 42 by the closed side outflow passage 65. ing.
- the outflow port 52 of the relief valve 5 is connected to the tank 44 by the tank path 43.
- the portion of the tank passage 43 on the relief valve 5 side merges with the portion on the upstream side of the closed side outflow passage 65 to form a common flow path.
- the tank 44 stores the hydraulic fluid flowing out of the relief valve 5 in a pressurized state.
- the pressure of the hydraulic fluid in the tank 7 is 0.2 to 0.3 MPa.
- the branch road 66 branches from the tank road 43, and this branch road 66 is connected to the first supply / discharge road 41. Therefore, check valves 73 and 74 are provided in the closed-side outflow passage 65 and the branch passage 66, respectively.
- the check valve 73 allows the flow from the relief valve 5 to the second supply / discharge passage 42, but prohibits the reverse flow, and the check valve 74 allows the flow from the tank passage 43 to the first supply / discharge passage 41. However, the reverse flow is prohibited.
- the pressure of the hydraulic fluid in the tank 44 is sufficiently higher than the cracking pressure of the check valves 73 and 74.
- the tank 7 for storing the hydraulic fluid flowing out from the relief valve 5 in a pressurized state since the tank 7 for storing the hydraulic fluid flowing out from the relief valve 5 in a pressurized state is provided, the pressure on the downstream side of the relief valve 5 can be kept high to some extent. This makes it possible to promote the inflow of the hydraulic fluid into the second operating chamber 32 when the relief valve 5 is opened.
- FIG. 4 shows a hydraulic surgical instrument 1C according to a third embodiment of the present invention.
- the same components as those in the first embodiment and the second embodiment are designated by the same reference numerals, and duplicate description will be omitted.
- the hydraulic surgical instrument 1C of the present embodiment has the open-side inflow path 61 and the open-side outflow path 62 described in the first embodiment, and the closed-side inflow path 64 and the closed-side outflow path 65 described in the second embodiment. It has a structure that combines.
- the open side inflow path 61 is provided with a check valve 75 that allows the flow from the second supply / discharge path 42 to the relief valve 5 but prohibits the reverse flow
- the closed side inflow path 64 is provided with a check valve 75. 1
- a check valve 76 is provided which allows a flow from the supply / discharge path 41 to the relief valve 5 but prohibits the reverse flow.
- the check valves 75, 71, 76, 73 are provided in the open-side inflow path 61, the open-side outflow path 62, the closed-side inflow path 64, and the closed-side outflow path 65, the open-side inflow path 61 and the open-side inflow path 61 and the open-side inflow path 61 are provided.
- the hydraulic fluid flows through the side outflow passage 62 only when the jaw 12 is opened, and the hydraulic fluid flows through the closed side inflow passage 64 and the closed side outflow passage 65 only when the jaw 12 is closed.
- the configuration is such that when the current supplied to the electric motor 81 when the control device 9 closes the jaw 12 reaches the upper limit as in the first embodiment, the current is maintained at the upper limit, the first supply is provided. Since the pressure of the exhaust passage 41 is electrically prevented from becoming too high, the closed side inflow passage 64 is unnecessary, and the check valve 75 does not need to be provided in the open side inflow passage 61.
- the relief valve 5 unless the relief valve 5 is configured to completely prevent leakage at a pressure lower than the set pressure, the relief valve 5 leaks the hydraulic fluid when the jaw 12 is closed. May occur. If a leak occurs in the relief valve 5, the pressure of the first supply / discharge passage 41 may decrease and the gripping force of the jaws 11 and 12 may not be maintained. On the other hand, in the first embodiment, since the inflow port 51 of the relief valve 5 is not connected to the first supply / discharge passage 41, the gripping force of the jaws 11 and 12 can be maintained when the jaw 12 is closed. .. That is, it is not necessary to configure the relief valve 5 so as to completely prevent leakage at a pressure lower than the set pressure, and a relief valve having a normal structure can be used as the relief valve 5.
- the hydraulic actuator 2 may be a cylinder type. In this case, the hydraulic actuator 2 may open and close both jaws 11 and 12.
- the piston 34 of the supply / discharge device 3 does not necessarily have to be driven by the drive device 8 including the electric motor 81, and the rod 83 to which the piston 34 is fixed may be manually operated.
- the hydraulic surgical instrument of the present invention has a hydraulic actuator including a first pressure chamber and a second pressure chamber that opens and closes at least one jaw, a cylinder, and a first operating chamber and a second operating chamber inside the cylinder.
- a supply / discharge device including a piston that partitions the chamber, a first supply / discharge passage that connects the first operating chamber to the first pressure chamber, and a second supply / discharge that connects the second operating chamber to the second pressure chamber.
- the relief valve opens when the pressure of the supply / discharge passage exceeds the set pressure of the relief valve while the inflow passage of the first supply / discharge passage and the second supply / discharge passage is connected.
- the hydraulic fluid flows from one supply / discharge passage to the other supply / discharge passage via the inflow passage, the relief valve and the outflow passage. Therefore, it is possible to prevent the pressure of the supply / discharge passage, which is the first supply / discharge passage or the second supply / discharge passage, from becoming too high.
- the first pressure chamber is a pressure chamber for closing the at least one jaw
- the second pressure chamber is a pressure chamber for opening the at least one jaw
- the inflow path is an inflow of the relief valve. It is a closed-side inflow path connecting the port to the first supply / discharge path
- the outflow path may be a closed-side outflow path connecting the outflow port of the relief valve to the second supply / discharge path. According to this configuration, it is possible to prevent the pressure of the first supply / discharge passage from becoming too high when the jaw is closed.
- the above-mentioned hydraulic surgical instrument has an open-side inflow path connecting the inflow port of the relief valve to the second supply / discharge path and an open-side outflow port connecting the outflow port of the relief valve to the first supply / discharge path.
- the opening side inflow passage is further provided with a check valve, which is provided with a check valve that allows a flow from the second supply / discharge passage to the relief valve but prohibits the reverse flow.
- the outflow passage is provided with a check valve that allows the flow from the relief valve to the first supply / discharge passage but prohibits the reverse flow, and the closed side inflow passage is provided with the first supply / discharge passage.
- a check valve is provided that allows the flow from the path to the relief valve but prohibits the reverse flow
- the closed-side outflow path allows the flow from the relief valve to the second supply / discharge path.
- a check valve may be provided to prohibit the reverse flow. According to this configuration, it is possible to prevent the pressure of the second supply / discharge passage from becoming too high when the jaw is opened.
- check valves are provided in the open inflow path, the open side outflow path, the closed side inflow path, and the closed side outflow path, the open side inflow path and the open side outflow path operate only when the jaws are opened. The liquid flows, and the hydraulic fluid flows in the closed inflow path and the closed outflow path only when the jaw is closed.
- the first pressure chamber is a pressure chamber for closing the at least one jaw
- the second pressure chamber is a pressure chamber for opening the at least one jaw
- the inflow path is an inflow of the relief valve. It is an open-side inflow path that connects the port to the second supply / discharge path
- the outflow path may be an open-side outflow path that connects the outflow port of the relief valve to the first supply / discharge path. According to this configuration, it is possible to prevent the pressure of the second supply / discharge passage from becoming too high when the jaw is opened.
- the hydraulic surgical instrument is a drive device that moves the piston in a closing direction from the second working chamber to the first working chamber and in an opening direction from the first working chamber to the second working chamber.
- the electric motor, a drive device including a linear motion mechanism for converting the rotational motion of the electric motor into a linear motion of the piston, and a control device for controlling the electric motor are further provided, and the control device is the control device.
- the control device is the control device.
- the hydraulic actuator may include a swinging vane that separates the first pressure chamber from the second pressure chamber.
- the hydraulic surgical instrument described above may further include a tank connected to the outflow port of the relief valve to store the hydraulic fluid flowing out of the relief valve in a pressurized state.
- a tank connected to the outflow port of the relief valve to store the hydraulic fluid flowing out of the relief valve in a pressurized state.
Landscapes
- Health & Medical Sciences (AREA)
- Surgery (AREA)
- Life Sciences & Earth Sciences (AREA)
- Medical Informatics (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Engineering & Computer Science (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- Ophthalmology & Optometry (AREA)
- Molecular Biology (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Public Health (AREA)
- Veterinary Medicine (AREA)
- Fluid-Pressure Circuits (AREA)
- Surgical Instruments (AREA)
Abstract
一実施形態に係る液圧式手術用器具(1A)は、ジョー(12)を開閉する液圧アクチュエータ(2)と、給排装置(3)を含む。液圧アクチュエータ(2)は第1圧力室(21)および第2圧力室(22)を含み、給排装置(3)はシリンダ(33)、およびシリンダ(33)の内部を第1作動室(31)および第2作動室(32)に仕切るピストン(34)を含む。第1作動室(31)は第1給排路(41)により第1圧力室(21)と接続され、第2作動(32)は第2給排路(42)により第2圧力室(22)と接続されている。また、手術用器具(1A)はリリーフ弁(5)を含み、リリーフ弁(5)の流入ポート(51)は流入路(61)により第2給排路(42)と接続され、リリーフ弁(5)の流出ポート(52)は流出路(62)により第1給排路(41)と接続されている。
Description
本発明は、液圧式手術用器具に関する。
従来から、グリッパーなどを構成する一対のジョーを液圧によって操作する液圧式手術用器具が知られている。例えば、特許文献1の図4には、一対のジョー(特許文献1では「バイオプシー顎部」と称呼)を開閉するシリンダタイプの液圧アクチュエータと、前記液圧アクチュエータに対する作動液の給排を行う給排装置を含む内視鏡装置が記載されている。
具体的に、特許文献1の図4に記載された内視鏡装置では、液圧アクチュエータが第1シリンダと、この第1シリンダの内部を第1圧力室と第2圧力室とに仕切る第1ピストンを含む。第1ピストンは、開閉機構を介して一対のジョーと連結されている。
給排装置は、第2シリンダと、この第2シリンダの内部を第1作動室と第2作動室とに仕切る第2ピストンを含む。第1作動室は第1給排路により第1圧力室と接続され、第2作動室は第2給排路により第2圧力室と接続されている。このような構成により、給排装置の第2ピストンを駆動することで、ジョーが開閉される。
しかしながら、特許文献1の図4に記載された内視鏡装置では、ジョーを閉じる際または開く際に第1給排路または第2給排路の圧力が高くなり過ぎることがある。第1給排路または第2給排路の圧力が高くなり過ぎると、ジョーや液圧機器などに不具合が生じるおそれがある。
そこで、本発明は、第1給排路または第2給排路の圧力が高くなり過ぎることを防止することができる液圧式手術用器具を提供することを目的とする。
前記課題を解決するために、本発明の液圧式手術用器具は、少なくとも1つのジョーを開閉する、第1圧力室および第2圧力室を含む液圧アクチュエータと、シリンダ、および前記シリンダの内部を第1作動室および第2作動室に仕切るピストンを含む給排装置と、前記第1作動室を前記第1圧力室と接続する第1給排路と、前記第2作動室を前記第2圧力室と接続する第2給排路と、リリーフ弁と、前記リリーフ弁の流入ポートを前記第1給排路と前記第2給排路の一方と接続する流入路と、前記リリーフ弁の流出ポートを前記第1給排路と前記第2給排路の他方と接続する流出路と、を備えることを特徴とする。
上記の構成によれば、第1給排路と第2給排路のうちの流入路がつながる方である一方給排路の圧力がリリーフ弁の設定圧を超えたときにリリーフ弁が開き、一方給排路から流入路、リリーフ弁および流出路を経由して他方給排路へ作動液が流れ込む。従って、第1給排路または第2給排路である一方給排路の圧力が高くなり過ぎることを防止することができる。
本発明によれば、第1給排路または第2給排路の圧力が高くなり過ぎることを防止することができる液圧式手術用器具が提供される。
(第1実施形態)
図1に、本発明の第1実施形態に係る液圧式手術用器具1Aを示す。手術用器具1Aは、グリッパーなどを構成する一対のジョー11,12を含む。ジョー11,12は、患部を挟むものであってもよいし、手術に用いられるクリップを潰すものであってもよい。本実施形態では、ジョー11が固定であり、ジョー12が開閉する。
図1に、本発明の第1実施形態に係る液圧式手術用器具1Aを示す。手術用器具1Aは、グリッパーなどを構成する一対のジョー11,12を含む。ジョー11,12は、患部を挟むものであってもよいし、手術に用いられるクリップを潰すものであってもよい。本実施形態では、ジョー11が固定であり、ジョー12が開閉する。
手術用器具1Aは、ジョー11,12の他に、ジョー12を開閉する液圧アクチュエータ2と、液圧アクチュエータ2に対する作動液の給排を行う給排装置3を含む。また、手術用器具1Aは、給排装置3を駆動する駆動装置8と、この駆動装置8を制御する制御装置9を含む。
手術用器具1Aで用いられる作動液は、特に限定されるものではないが、例えば、生理食塩水や油などである。
図示は省略するが、手術用器具1Aは、駆動ユニットと、この駆動ユニットから延びて患者の体内に挿入される挿入管を含む。給排装置3および駆動装置8は駆動ユニット内に設けられ、液圧アクチュエータ2およびジョー11,12は挿入管の先端に設けられる。なお、駆動ユニット内には、後述するリリーフ弁5、チェック弁71,72およびタンク44も設けられる。
例えば、駆動ユニットは手術ロボットに取り付けられる。この場合、駆動装置8の後述する直動機構82が駆動ユニット内に設けられ、駆動装置8の後述する電動モータ81が手術ロボットに設けられてもよい。あるいは、直動機構82の後述するロッド83を駆動ユニット内に設け、直動機構82のその他の部分および電動モータ81を手術ロボットに設けることも可能である。
液圧アクチュエータ2は、ジョー12を閉じるための第1圧力室21と、ジョー12を開くための第2圧力室22を含む。本実施形態では、液圧アクチュエータ2がベーンタイプであり、第1圧力室21と第2圧力室22とが、揺動するベーン23によって仕切られている。ベーン23は、中空のハウジング24内に配置されている。上述したジョー11は、ハウジング24に固定されている。
より詳しくは、ベーン23は図略の揺動軸に固定されており、その揺動軸がハウジング24に回転可能に支持されている。揺動軸の少なくとも一端はハウジング24の外に位置しており、この一端にジョー12が固定されている。つまり、ジョー12はベーン23と共に揺動する。
ハウジング24は、前記揺動軸の軸方向から見たときに扇形状または半円状の内部空間を有し、この内部空間がベーン23によって第1圧力室21と第2圧力室22とに仕切られている。内部空間が扇形状である場合、その中心角度はジョー12の開閉角度(ベーン23の揺動角度)とほぼ同じであってもよい。この場合、ジョー12が最大に開いたときに、ベーン23が内部空間の一方の壁面に当接してもよい。換言すれば、内部空間の一方の壁面がベーン23の開き側ストッパーとして機能してもよい。
あるいは、内部空間が半円状である場合、第1圧力室21内に、ジョー12が最大に開いたときにベーン23と当接するストッパーが設けられてもよい。
給排装置3は、シリンダ33と、このシリンダ33の内部を第1作動室31と第2作動室32とに仕切るピストン34を含む。シリンダ33は、ピストン34を摺動可能に保持するチューブと、そのチューブの両端を閉塞する一対の端板を含む。
第1作動室31は第1給排路41により第1圧力室21と接続されており、第2作動室32は第2給排路42により第2圧力室22と接続されている。
さらに、手術用器具1Aは、流入ポート51および流出ポート52を有するリリーフ弁5を含む。本実施形態では、流入ポート51が開き側流入路61により第2給排路42と接続され、流出ポート52が開き側流出路62により第1給排路41と接続されている。
さらに、本実施形態では、リリーフ弁5の流出ポート52がタンク路43によりタンク44と接続されている。タンク路43のリリーフ弁5側の部分は、開き側流出路62の上流側部分と合流して共通の流路となっている。
タンク44は、リリーフ弁5から流出する作動液を加圧された状態で貯留する。例えば、タンク7内の作動液の圧力は、0.2~0.3MPaである。
本実施形態では、タンク路43から分岐路63が分岐しており、この分岐路63が第2給排路42につながっている。このため、開き側流出路62および分岐路63にはチェック弁71,72がそれぞれ設けられている。チェック弁71は、リリーフ弁5から第1給排路41へ向かう流れは許容するがその逆の流れは禁止し、チェック弁72は、タンク路43から第2給排路42へ向かう流れは許容するがその逆の流れは禁止する。なお、タンク44内の作動液の圧力は、チェック弁71,72のクラッキング圧よりも十分に高い。
上述した駆動装置8は、給排装置3のピストン34を第2作動室32から第1作動室31へ向かう閉方向および第1作動室31から第2作動室32へ向かう開方向へ移動する。本実施形態では、駆動装置8が、電動モータ81と、電動モータ81の回転運動をピストン34の直線運動に変換する直動機構82を含む。ただし、駆動装置8の構成はこれに限られるものではなく、適宜変更可能である。
直動機構82はピストン34が固定されたロッド83を有する。本実施形態では、ロッド83がシリンダ33の直動機構82側の端板のみを貫通する。ただし、ロッド83は、シリンダ33の双方の端板を貫通してもよい。例えば、直動機構82は、ねじ軸とこのねじ軸と螺合するナット部材を有してもよいし、互いに噛み合うラックおよびピニオンを有してもよい。
上述した制御装置9は、駆動装置8の電動モータ81を制御する。制御装置9には、ジョー12に対する開指令および閉指令が入力される。例えば、制御装置9は、ROMやRAMなどのメモリと、HDDやSSDなどのストレージと、CPUを有するコンピュータであり、ROMまたはストレージに記憶されたプログラムがCPUにより実行される。
次に、図2(a)~(c)を参照して、手術用器具1Aの動作を説明する。
制御装置9に閉指令が入力されると、制御装置9は、図2(a)に示すようにピストン34が閉方向に移動するように電動モータ81を制御する。これにより、第1作動室31から第1給排路41を通じて第1圧力室21へ作動液が供給されるとともに、第2圧力室22から第2給排路42を通じて第2作動室32へ作動液が排出される。その結果、ジョー12が、ピストン34の移動に同期して閉じる。
上述したようにロッド83はシリンダ33の一方の端板のみを貫通するので、ピストン34が移動すると、ロッド83における第2作動室32内へ新たに侵入する部分の体積だけ、第1作動室31、第1給排路41、第1圧力室21、第2圧力室22、第2給排路42および第2作動室32の体積の合計が減少する。また、第1作動室31からの作動液の流出流量Q1は、第2作動室32への作動液の流入流量Q2よりも大きい。
このような現象により、摩擦を無視し、ジョー12に外力が加わらず、ピストン34およびベーン23が準静的に移動すると仮定した場合、ジョー12が可動域終端に達するまでは、第1圧力室21と第2圧力室22の圧力がともに等しく上昇し、液圧アクチュエータ2の流出入流量Q3が第1作動室31からの作動液の流出流量Q1よりも小さく、かつ第2作動室32への作動液の流入流量Q2よりも大きくなるようにベーン23が移動する。なお、Q1とQ3の差分は第1給排路41内の作動液の体積変化で吸収され、Q3とQ2の差分は第2給排路42内の作動液の体積変化で吸収される。
実際には、第2圧力室22の方が第1圧力室21よりも、ジョー12が受ける反力と可動部および作動液の摩擦力の合計から慣性力を引いた力に相当する圧力だけ高く、その差を保ったまま第2圧力室22と第1圧力室21の圧力がともに上昇する。ジョー12が可動域終端に達するか、ジョー12が受ける反力によりベーン23が動かなくなると、ピストン34が移動するに従って第2圧力室22の圧力が下がり、第1圧力室21と第2圧力室22との間に第1圧力室21の圧力の方が高い差圧が生じてジョー12が把持力を発揮する。なお、第1圧力室21と第2圧力室22との間の差圧が大きくなると、図2(a)中に矢印で示すように液圧アクチュエータ2内で内部リークが生じる。
本実施形態では、制御装置9が、ジョー12を閉じる際に第1給排路41の圧力が高くなり過ぎることを防止するための制御を行う。具体的に、制御装置9は、ジョー12を閉じる際に、電動モータ81へ送給する電流が上限に到達したときはその電流を前記上限に保つ。これにより、ジョー12を閉じる際に第1給排路41の圧力が高くなり過ぎることを防止することができる。
制御装置9に開指令が入力されると、制御装置9は、図2(b)に示すようにピストン34が開方向に移動するように電動モータ81を制御する。これにより、第2作動室32から第2給排路42を通じて第2圧力室22へ作動液が供給されるとともに、第1圧力室21から第1給排路41を通じて第1作動室31へ作動液が排出される。その結果、ジョー12が、ピストン34の移動に同期して開く。
上述したようにロッド83はシリンダ33の一方の端板のみを貫通するので、第1作動室31への作動液の流入流量Q1は、第2作動室32からの作動液の流出流量Q2よりも大きい。流入流量Q1と流出流量Q2の差分である不足分の作動液は、タンク44からタンク路43および開き側流出路62を通じて第1給排路41へ供給される。
制御装置9に開指令が入力されている間に、ジョー12を開くときの負荷が大きくなると、図2(c)に示すように第2給排路42の圧力がリリーフ弁5の設定圧(例えば、14~15MPa)を超えたときにリリーフ弁5が開き、第2給排路42から開き側流入路61、リリーフ弁5および開き側流出路62を経由して第1給排路41へ作動液が流れ込む。
このように、本実施形態では、ジョー12を開く際に第2給排路42の圧力が高くなり過ぎることを防止することができる。
しかも、本実施形態では、リリーフ弁5から流出する作動液を加圧された状態で貯留するタンク44が設けられているので、リリーフ弁5の下流側の圧力をある程度高く保つことができる。これにより、リリーフ弁5が開いたときの第1作動室31への作動液の流入を促進することができる。
(第2実施形態)
図3に、本発明の第2実施形態に係る液圧式手術用器具1Bを示す。なお、本実施形態において、第1実施形態と同一構成要素には同一符号を付し、重複した説明は省略する。
図3に、本発明の第2実施形態に係る液圧式手術用器具1Bを示す。なお、本実施形態において、第1実施形態と同一構成要素には同一符号を付し、重複した説明は省略する。
本実施形態では、リリーフ弁5の流入ポート51が閉じ側流入路64により第1給排路41と接続されるとともに、流出ポート52が閉じ側流出路65により第2給排路42と接続されている。
さらに、本実施形態でも第1実施形態と同様に、リリーフ弁5の流出ポート52がタンク路43によりタンク44と接続されている。タンク路43のリリーフ弁5側の部分は、閉じ側流出路65の上流側部分と合流して共通の流路となっている。
第1実施形態で説明したように、タンク44はリリーフ弁5から流出する作動液を加圧された状態で貯留する。例えば、タンク7内の作動液の圧力は、0.2~0.3MPaである。
本実施形態では、タンク路43から分岐路66が分岐しており、この分岐路66が第1給排路41につながっている。このため、閉じ側流出路65および分岐路66にはチェック弁73,74がそれぞれ設けられている。チェック弁73は、リリーフ弁5から第2給排路42へ向かう流れは許容するがその逆の流れは禁止し、チェック弁74は、タンク路43から第1給排路41へ向かう流れは許容するがその逆の流れは禁止する。なお、タンク44内の作動液の圧力は、チェック弁73,74のクラッキング圧よりも十分に高い。
本実施形態では、制御装置9に閉指令が入力されている間に、ジョー12を閉じるときの負荷が大きくなると、第1給排路41の圧力がリリーフ弁5の設定圧を超えたときにリリーフ弁5が開き、第1給排路41から閉じ側流入路64、リリーフ弁5および閉じ側流出路65を経由して第2給排路42へ作動液が流れ込む。
このように、本実施形態では、ジョーを閉じる際に第1給排路41の圧力が高くなり過ぎることを防止することができる。
しかも、本実施形態では、リリーフ弁5から流出する作動液を加圧された状態で貯留するタンク7が設けられているので、リリーフ弁5の下流側の圧力をある程度高く保つことができる。これにより、リリーフ弁5が開いたときの第2作動室32への作動液の流入を促進することができる。
(第3実施形態)
図4に、本発明の第3実施形態に係る液圧式手術用器具1Cを示す。なお、本実施形態において、第1実施形態および第2実施形態と同一構成要素には同一符号を付し、重複した説明は省略する。
図4に、本発明の第3実施形態に係る液圧式手術用器具1Cを示す。なお、本実施形態において、第1実施形態および第2実施形態と同一構成要素には同一符号を付し、重複した説明は省略する。
本実施形態の液圧式手術用器具1Cは、第1実施形態で説明した開き側流入路61および開き側流出路62と、第2実施形態で説明した閉じ側流入路64および閉じ側流出路65を組み合わせた構成を有する。
開き側流入路61と閉じ側流入路64の下流側部分は互いに合流して共通の流路となっている。同様に、開き側流出路62と閉じ側流出路65の上流側部分は互いに合流して共通の流路となっている。
開き側流入路61には、第2給排路42からリリーフ弁5へ向かう流れは許容するがその逆の流れは禁止するチェック弁75が設けられており、閉じ側流入路64には、第1給排路41からリリーフ弁5へ向かう流れは許容するがその逆の流れは禁止するチェック弁76が設けられている。
本実施形態では、第1実施形態で説明したジョー12を開く際に第2給排路42の圧力が高くなり過ぎることを防止することができるという効果と、第2実施形態で説明したジョー12を閉じる際に第1給排路41の圧力が高くなり過ぎることを防止することができるという効果の双方を得ることができる。
しかも、開き側流入路61、開き側流出路62、閉じ側流入路64および閉じ側流出路65にはチェック弁75,71,76,73が設けられているので、開き側流入路61および開き側流出路62にはジョー12を開くときのみに作動液が流れ、閉じ側流入路64および閉じ側流出路65にはジョー12を閉じるときのみに作動液が流れる。
ただし、第1実施形態のような、制御装置9がジョー12を閉じる際に電動モータ81へ送給する電流が上限に到達したときはその電流を前記上限に保つ構成であれば、第1給排路41の圧力が高くなり過ぎることを電気的に防止するので、閉じ側流入路64が不要であるとともに、開き側流入路61にチェック弁75を設ける必要がない。
また、第2実施形態および第3実施形態では、リリーフ弁5を設定圧よりも低い圧力での漏れを完全に防ぐように構成しない限り、ジョー12を閉じる際にリリーフ弁5で作動液の漏れが生じることがある。リリーフ弁5で漏れが生じると、第1給排路41の圧力が低下してジョー11,12による把持力が保持できなくなるおそれがある。これに対し、第1実施形態では、リリーフ弁5の流入ポート51が第1給排路41に接続されていないので、ジョー12を閉じる際にジョー11,12による把持力を保持することができる。すなわち、リリーフ弁5を設定圧よりも低い圧力での漏れを完全に防ぐように構成する必要がなく、リリーフ弁5として通常の構造のリリーフ弁を用いることができる。
(その他の実施形態)
本発明は上述した実施形態に限定されるものではなく、本発明の要旨を逸脱しない範囲で種々の変形が可能である。
本発明は上述した実施形態に限定されるものではなく、本発明の要旨を逸脱しない範囲で種々の変形が可能である。
例えば、液圧アクチュエータ2はシリンダタイプのものであってもよい。この場合、液圧アクチュエータ2は、双方のジョー11,12を開閉してもよい。
また、給排装置3のピストン34は、必ずしも電動モータ81を含む駆動装置8により駆動される必要はなく、ピストン34が固定されたロッド83が手動で操作されてもよい。
(まとめ)
本発明の液圧式手術用器具は、少なくとも1つのジョーを開閉する、第1圧力室および第2圧力室を含む液圧アクチュエータと、シリンダ、および前記シリンダの内部を第1作動室および第2作動室に仕切るピストンを含む給排装置と、前記第1作動室を前記第1圧力室と接続する第1給排路と、前記第2作動室を前記第2圧力室と接続する第2給排路と、リリーフ弁と、前記リリーフ弁の流入ポートを前記第1給排路と前記第2給排路の一方と接続する流入路と、前記リリーフ弁の流出ポートを前記第1給排路と前記第2給排路の他方と接続する流出路と、を備える、ことを特徴とする。
本発明の液圧式手術用器具は、少なくとも1つのジョーを開閉する、第1圧力室および第2圧力室を含む液圧アクチュエータと、シリンダ、および前記シリンダの内部を第1作動室および第2作動室に仕切るピストンを含む給排装置と、前記第1作動室を前記第1圧力室と接続する第1給排路と、前記第2作動室を前記第2圧力室と接続する第2給排路と、リリーフ弁と、前記リリーフ弁の流入ポートを前記第1給排路と前記第2給排路の一方と接続する流入路と、前記リリーフ弁の流出ポートを前記第1給排路と前記第2給排路の他方と接続する流出路と、を備える、ことを特徴とする。
上記の構成によれば、第1給排路と第2給排路のうちの流入路がつながる方である一方給排路の圧力がリリーフ弁の設定圧を超えたときにリリーフ弁が開き、一方給排路から流入路、リリーフ弁および流出路を経由して他方給排路へ作動液が流れ込む。従って、第1給排路または第2給排路である一方給排路の圧力が高くなり過ぎることを防止することができる。
前記第1圧力室は前記少なくとも1つのジョーを閉じるための圧力室であり、前記第2圧力室は前記少なくとも1つのジョーを開くための圧力室であり、前記流入路は、前記リリーフ弁の流入ポートを前記第1給排路と接続する閉じ側流入路であり、前記流出路は、前記リリーフ弁の流出ポートを前記第2給排路と接続する閉じ側流出路であってもよい。この構成によれば、ジョーを閉じる際に第1給排路の圧力が高くなり過ぎることを防止することができる。
上記の液圧式手術用器具は、前記リリーフ弁の流入ポートを前記第2給排路と接続する開き側流入路と、前記リリーフ弁の流出ポートを前記第1給排路と接続する開き側流出路と、をさらに備え、前記開き側流入路には、前記第2給排路から前記リリーフ弁へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、前記開き側流出路には、前記リリーフ弁から前記第1給排路へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、前記閉じ側流入路には、前記第1給排路から前記リリーフ弁へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、前記閉じ側流出路には、前記リリーフ弁から前記第2給排路へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられてもよい。この構成によれば、ジョーを開く際に第2給排路の圧力が高くなり過ぎることを防止することができる。しかも、開き側流入路、開き側流出路、閉じ側流入路および閉じ側流出路にはチェック弁が設けられているので、開き側流入路および開き側流出路にはジョーを開くときのみに作動液が流れ、閉じ側流入路および閉じ側流出路にはジョーを閉じるときのみに作動液が流れる。
前記第1圧力室は前記少なくとも1つのジョーを閉じるための圧力室であり、前記第2圧力室は前記少なくとも1つのジョーを開くための圧力室であり、前記流入路は、前記リリーフ弁の流入ポートを前記第2給排路と接続する開き側流入路であり、前記流出路は、前記リリーフ弁の流出ポートを前記第1給排路と接続する開き側流出路であってもよい。この構成によれば、ジョーを開く際に第2給排路の圧力が高くなり過ぎることを防止することができる。
上記の液圧式手術用器具は、前記ピストンを前記第2作動室から前記第1作動室へ向かう閉方向および前記第1作動室から前記第2作動室へ向かう開方向へ移動する駆動装置であって、電動モータ、および前記電動モータの回転運動を前記ピストンの直線運動に変換する直動機構を含む駆動装置と、前記電動モータを制御する制御装置と、をさらに備え、前記制御装置は、前記少なくとも1つのジョーを閉じる際に、前記電動モータへ送給する電流が上限に到達したときはその電流を前記上限に保ってもよい。この構成によれば、ジョーを閉じる際に第1給排路の圧力が高くなり過ぎることを防止することができる。しかも、第1給排路の圧力が高くなり過ぎることを電気的に防止するので、閉じ側流入路が不要であるとともに、開き側流入路にチェック弁を設ける必要がない。
例えば、前記液圧アクチュエータは、前記第1圧力室と前記第2圧力室を仕切る、揺動するベーンを含んでもよい。
上記の液圧式手術用器具は、前記リリーフ弁の流出ポートと接続された、前記リリーフ弁から流出する作動液を加圧された状態で貯留するタンクをさらに備えてもよい。この構成によれば、リリーフ弁の下流側の圧力をある程度高く保つことができ、リリーフ弁が開いたときの第1作動室または第2作動室への作動液の流入を促進することができる。
Claims (7)
- 少なくとも1つのジョーを開閉する、第1圧力室および第2圧力室を含む液圧アクチュエータと、
シリンダ、および前記シリンダの内部を第1作動室および第2作動室に仕切るピストンを含む給排装置と、
前記第1作動室を前記第1圧力室と接続する第1給排路と、
前記第2作動室を前記第2圧力室と接続する第2給排路と、
リリーフ弁と、
前記リリーフ弁の流入ポートを前記第1給排路と前記第2給排路の一方と接続する流入路と、
前記リリーフ弁の流出ポートを前記第1給排路と前記第2給排路の他方と接続する流出路と、
を備える、液圧式手術用器具。 - 前記第1圧力室は前記少なくとも1つのジョーを閉じるための圧力室であり、前記第2圧力室は前記少なくとも1つのジョーを開くための圧力室であり、
前記流入路は、前記リリーフ弁の流入ポートを前記第1給排路と接続する閉じ側流入路であり、
前記流出路は、前記リリーフ弁の流出ポートを前記第2給排路と接続する閉じ側流出路である、請求項1に記載の液圧式手術用器具。 - 前記リリーフ弁の流入ポートを前記第2給排路と接続する開き側流入路と、
前記リリーフ弁の流出ポートを前記第1給排路と接続する開き側流出路と、をさらに備え、
前記開き側流入路には、前記第2給排路から前記リリーフ弁へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、
前記開き側流出路には、前記リリーフ弁から前記第1給排路へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、
前記閉じ側流入路には、前記第1給排路から前記リリーフ弁へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられており、
前記閉じ側流出路には、前記リリーフ弁から前記第2給排路へ向かう流れは許容するがその逆の流れは禁止するチェック弁が設けられている、請求項2に記載の液圧式手術用器具。 - 前記第1圧力室は前記少なくとも1つのジョーを閉じるための圧力室であり、前記第2圧力室は前記少なくとも1つのジョーを開くための圧力室であり、
前記流入路は、前記リリーフ弁の流入ポートを前記第2給排路と接続する開き側流入路であり、
前記流出路は、前記リリーフ弁の流出ポートを前記第1給排路と接続する開き側流出路である、請求項1に記載の液圧式手術用器具。 - 前記ピストンを前記第2作動室から前記第1作動室へ向かう閉方向および前記第1作動室から前記第2作動室へ向かう開方向へ移動する駆動装置であって、電動モータ、および前記電動モータの回転運動を前記ピストンの直線運動に変換する直動機構を含む駆動装置と、
前記電動モータを制御する制御装置と、をさらに備え、
前記制御装置は、前記少なくとも1つのジョーを閉じる際に、前記電動モータへ送給する電流が上限に到達したときはその電流を前記上限に保つ、請求項4に記載の液圧式手術用器具。 - 前記液圧アクチュエータは、前記第1圧力室と前記第2圧力室を仕切る、揺動するベーンを含む、請求項1~5の何れか一項に記載の液圧式手術用器具。
- 前記リリーフ弁の流出ポートと接続された、前記リリーフ弁から流出する作動液を加圧された状態で貯留するタンクをさらに備える、請求項1~6の何れか一項に記載の液圧式手術用器具。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2020218631A JP2022103785A (ja) | 2020-12-28 | 2020-12-28 | 液圧式手術用器具 |
| JP2020-218631 | 2020-12-28 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022145104A1 true WO2022145104A1 (ja) | 2022-07-07 |
Family
ID=82259412
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2021/037840 Ceased WO2022145104A1 (ja) | 2020-12-28 | 2021-10-13 | 液圧式手術用器具 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP2022103785A (ja) |
| WO (1) | WO2022145104A1 (ja) |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5361583A (en) * | 1993-09-30 | 1994-11-08 | Ethicon, Inc. | Pressurized fluid actuation system with variable force and stroke output for use in a surgical instrument |
| JP2006500986A (ja) * | 2002-09-30 | 2006-01-12 | サイトライン テクノロジーズ リミテッド | ピストンにより駆動される内視鏡ツール |
-
2020
- 2020-12-28 JP JP2020218631A patent/JP2022103785A/ja active Pending
-
2021
- 2021-10-13 WO PCT/JP2021/037840 patent/WO2022145104A1/ja not_active Ceased
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5361583A (en) * | 1993-09-30 | 1994-11-08 | Ethicon, Inc. | Pressurized fluid actuation system with variable force and stroke output for use in a surgical instrument |
| JP2006500986A (ja) * | 2002-09-30 | 2006-01-12 | サイトライン テクノロジーズ リミテッド | ピストンにより駆動される内視鏡ツール |
Also Published As
| Publication number | Publication date |
|---|---|
| JP2022103785A (ja) | 2022-07-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP2008524535A (ja) | 油圧駆動装置 | |
| US20230356557A1 (en) | Hydraulic Fluid Supply System, In Particular For A Suspension System | |
| CN108138809B (zh) | 流体压控制装置 | |
| JP5011315B2 (ja) | 油圧作業機の振動抑制装置および油圧作業機 | |
| CN101688544B (zh) | 流体压力驱动单元和除雪单元 | |
| JP6159629B2 (ja) | 流体圧制御装置 | |
| JP7575213B2 (ja) | 複動空気圧シリンダ用流体戻し装置及び複動空気圧シリンダの動作方法 | |
| JP6788395B2 (ja) | シリンダ駆動装置 | |
| CN120042821B (zh) | 一种主被动结合的电液执行器及其方法 | |
| KR20120120286A (ko) | 밸브에서의 유체 작동식 작동 드라이브 | |
| JP2022103785A (ja) | 液圧式手術用器具 | |
| JP6093535B2 (ja) | シリンダ駆動装置 | |
| JP2008051194A (ja) | 油圧シリンダ及び油圧駆動装置 | |
| US20080054203A1 (en) | Valve arrangement | |
| KR101633755B1 (ko) | 동력 보상 회로를 구비한 이중화 전기 유체 정역학 액츄에이터 장치 및 그 제어 방법 | |
| US7347117B2 (en) | Hydraulic linear drive of a transmission actuator | |
| WO2022145103A1 (ja) | 液圧式手術用器具 | |
| CN111566357B (zh) | 带液压排流增益器的执行驱动装置 | |
| WO2018025546A1 (ja) | 油圧駆動装置 | |
| JP2017062010A (ja) | 流体圧制御装置 | |
| JP6706170B2 (ja) | 流体圧制御装置 | |
| JP2020002647A (ja) | 作業機械のアタッチメント、並びに、作業機械のアタッチメント用油圧作動弁 | |
| JP6666167B2 (ja) | 液圧アクチュエータ | |
| KR970029950A (ko) | 가스차단기 및 이에 사용되는 유체압 구동장치 | |
| CN119021304A (zh) | 驱动装置及驱动装置的控制方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21914965 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 21914965 Country of ref document: EP Kind code of ref document: A1 |