WO2019230681A1 - 機器ユニット - Google Patents
機器ユニット Download PDFInfo
- Publication number
- WO2019230681A1 WO2019230681A1 PCT/JP2019/020995 JP2019020995W WO2019230681A1 WO 2019230681 A1 WO2019230681 A1 WO 2019230681A1 JP 2019020995 W JP2019020995 W JP 2019020995W WO 2019230681 A1 WO2019230681 A1 WO 2019230681A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- characteristic data
- recording medium
- casing
- flow rate
- command current
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B15/00—Systems controlled by a computer
- G05B15/02—Systems controlled by a computer electric
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B23/00—Pumping installations or systems
- F04B23/04—Combinations of two or more pumps
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B49/00—Control, e.g. of pump delivery, or pump pressure of, or safety measures for, machines, pumps, or pumping installations, not otherwise provided for, or of interest apart from, groups F04B1/00 - F04B47/00
- F04B49/06—Control using electricity
- F04B49/065—Control using electricity and making use of computers
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B49/00—Control, e.g. of pump delivery, or pump pressure of, or safety measures for, machines, pumps, or pumping installations, not otherwise provided for, or of interest apart from, groups F04B1/00 - F04B47/00
- F04B49/22—Control, e.g. of pump delivery, or pump pressure of, or safety measures for, machines, pumps, or pumping installations, not otherwise provided for, or of interest apart from, groups F04B1/00 - F04B47/00 by means of valves
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B53/00—Component parts, details or accessories not provided for in, or of interest apart from, groups F04B1/00 - F04B23/00 or F04B39/00 - F04B47/00
- F04B53/10—Valves; Arrangement of valves
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16K—VALVES; TAPS; COCKS; ACTUATING-FLOATS; DEVICES FOR VENTING OR AERATING
- F16K27/00—Construction of housing; Use of materials therefor
- F16K27/04—Construction of housing; Use of materials therefor of sliding valves
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16K—VALVES; TAPS; COCKS; ACTUATING-FLOATS; DEVICES FOR VENTING OR AERATING
- F16K37/00—Special means in or on valves or other cut-off apparatus for indicating or recording operation thereof, or for enabling an alarm to be given
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06K—GRAPHICAL DATA READING; PRESENTATION OF DATA; RECORD CARRIERS; HANDLING RECORD CARRIERS
- G06K19/00—Record carriers for use with machines and with at least a part designed to carry digital markings
- G06K19/06—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code
- G06K19/06009—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code with optically detectable marking
- G06K19/06018—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code with optically detectable marking one-dimensional coding
- G06K19/06028—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code with optically detectable marking one-dimensional coding using bar codes
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06K—GRAPHICAL DATA READING; PRESENTATION OF DATA; RECORD CARRIERS; HANDLING RECORD CARRIERS
- G06K19/00—Record carriers for use with machines and with at least a part designed to carry digital markings
- G06K19/06—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code
- G06K19/06009—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code with optically detectable marking
- G06K19/06037—Record carriers for use with machines and with at least a part designed to carry digital markings characterised by the kind of the digital marking, e.g. shape, nature, code with optically detectable marking multi-dimensional coding
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06K—GRAPHICAL DATA READING; PRESENTATION OF DATA; RECORD CARRIERS; HANDLING RECORD CARRIERS
- G06K7/00—Methods or arrangements for sensing record carriers, e.g. for reading patterns
- G06K7/10—Methods or arrangements for sensing record carriers, e.g. for reading patterns by electromagnetic radiation, e.g. optical sensing; by corpuscular radiation
- G06K7/14—Methods or arrangements for sensing record carriers, e.g. for reading patterns by electromagnetic radiation, e.g. optical sensing; by corpuscular radiation using light without selection of wavelength, e.g. sensing reflected white light
- G06K7/1404—Methods for optical code recognition
- G06K7/1408—Methods for optical code recognition the method being specifically adapted for the type of code
- G06K7/1413—1D bar codes
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06K—GRAPHICAL DATA READING; PRESENTATION OF DATA; RECORD CARRIERS; HANDLING RECORD CARRIERS
- G06K7/00—Methods or arrangements for sensing record carriers, e.g. for reading patterns
- G06K7/10—Methods or arrangements for sensing record carriers, e.g. for reading patterns by electromagnetic radiation, e.g. optical sensing; by corpuscular radiation
- G06K7/14—Methods or arrangements for sensing record carriers, e.g. for reading patterns by electromagnetic radiation, e.g. optical sensing; by corpuscular radiation using light without selection of wavelength, e.g. sensing reflected white light
- G06K7/1404—Methods for optical code recognition
- G06K7/1408—Methods for optical code recognition the method being specifically adapted for the type of code
- G06K7/1417—2D bar codes
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B2205/00—Fluid parameters
- F04B2205/05—Pressure after the pump outlet
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B2205/00—Fluid parameters
- F04B2205/09—Flow through the pump
Definitions
- the present invention relates to a device unit including two or more devices connected to each other.
- FIG. 3 of Patent Document 1 discloses a device (valve device) in which three proportional solenoid valves are incorporated in one casing.
- a recording medium on which characteristic data (relationship between command current and output pressure) of three proportional solenoid valves is recorded by a barcode is attached to the side surface of the casing.
- the characteristic data recorded on the recording medium is read by a reading device (for example, a barcode reader), and a command current is supplied to those proportional solenoid valves.
- a reading device for example, a barcode reader
- a command current is supplied to those proportional solenoid valves.
- an object of the present invention is to provide a device unit that can efficiently read characteristic data of two or more devices.
- the device unit of the present invention includes two or more devices each including an independent casing connected to each other, and one of the casings of one of the two or more devices.
- One aspect is characterized in that two or more recording media each recording the characteristic data of the two or more devices or the storage destination IP addresses of the characteristic data are attached adjacent to each other.
- a storage destination IP address of device characteristic data corresponding to each recording medium is directly recorded.
- the characteristic data of two or more devices can be read via the Internet. Moreover, since these recording media are attached adjacent to one side of the casing of one device, the characteristic data of two or more devices can be efficiently read in a short time.
- each of the two or more devices is a pump whose discharge flow rate changes according to a command current, and the characteristic data of the device is a relationship between the command current and a discharge flow rate at a specific discharge pressure. There may be.
- the specific discharge pressure may be two different discharge pressures. According to this configuration, calibration according to the discharge pressure of the pump can also be performed.
- each of the two or more devices is a multi-control valve that includes a plurality of spools that change a passage flow rate according to a command current, and the characteristic data of the devices includes the command data in each of the plurality of spools. It may be a relationship between current and the passing flow rate.
- the date when the characteristic data of the corresponding device is measured may be recorded so as to be visible.
- the characteristic data is also remeasured. Since the remeasured date is recorded in the corresponding recording medium so as to be visible, the user can grasp the repair history of the device by looking at the recording medium. Therefore, maintainability on site is improved.
- the two or more recording media may be integrated. According to this configuration, a single object can be used as two or more recording media.
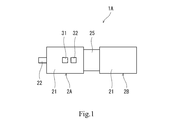
- FIG. 1 shows a device unit 1A according to the first embodiment of the present invention.
- the device unit 1A includes a first device 2A and a second device 2B that are connected to each other.
- the device unit 1A may include three or more devices connected to each other.
- each of the first device 2A and the second device 2B is a variable displacement swash plate pump in which the discharge flow rate changes according to the command current.
- each of the first device 2A and the second device 2B may be an oblique axis pump.
- each of the first device 2A and the second device 2B includes a casing 21 that is independent of each other.
- Each casing 21 is a hexahedron having, for example, six side surfaces.
- One side surface of the casing 21 of the first device 2A and one side surface of the casing 21 of the second device 2B are opposed to each other with the intermediate casing 25 interposed therebetween.
- a cylinder fixed to the rotating shaft 22 a plurality of pistons held by the cylinder, and a chute attached to the tip of each piston slide.
- a swash plate is arranged.
- a cylinder fixed to a rotating shaft (not shown), a plurality of pistons held by the cylinder, a chute and a slide attached to the tip of each piston.
- a moving swash plate is arranged.
- the rotation shaft of the second device 2B is connected to the rotation shaft 22 of the first device 2A within the intermediate casing 25.
- Each of the casing 21 of the first device 2A and the casing 21 of the second device 2B is incorporated with a servo mechanism that changes the angle of the swash plate with respect to a plane orthogonal to the center line of the rotation axis in accordance with the command current.
- the servo mechanism may be configured to electrically change the hydraulic pressure acting on the servo piston connected to the swash plate, or may include an electric actuator connected to the swash plate.
- a first recording medium 31 and a second recording medium 32 are attached adjacent to each other on one side surface of the casing 21 of the first device 2A.
- the first recording medium 31 and the second recording medium 32 may be attached adjacent to one side surface of the casing 21 of the second device 2B.
- the characteristic data of the first device 2A is recorded on the first recording medium 31 with a barcode
- the characteristic data of the second device 2B is recorded on the second recording medium 32 with a barcode
- the barcode is a matrix type two-dimensional code (QR code (registered trademark)).
- the first recording medium 31 and the second recording medium 32 are separate bodies. However, the first recording medium 31 and the second recording medium 32 may be integrated. In this case, a single object can be used as the two recording media 31 and 32.
- the attachment of the first recording medium 31 and the second recording medium 32 to the casing 21 may be, for example, affixed with an adhesive or a double-sided tape, or may be screwed.
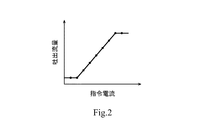
- Each of the characteristic data of the first device 2A and the characteristic data of the second device 2B described above is a relationship between the command current and the discharge flow rate at a specific discharge pressure, as shown in FIG.
- the characteristic data is discrete data as indicated by a plurality of points in FIG. 2, and is measured at a factory before shipment of the corresponding device (2A or 2B). In addition, when the device is repaired (for example, part replacement), the characteristic data is also remeasured.
- each of the first recording medium 31 and the second recording medium 32 the date when the characteristic data of the corresponding device (2A or 2B) is measured is recorded so as to be visible. Further, identification data (individual product number) of the corresponding device (2A or 2B) is also recorded on each of the first recording medium 31 and the second recording medium 32.
- the characteristic data of the first device 2A recorded on the first recording medium 31 includes the relationship between the command current and the discharge flow rate at a relatively low first discharge pressure (for example, 8 MPa), and the relatively high first data.
- the relationship between the command current and the discharge flow rate at two discharge pressures is included.
- the characteristic data of the second device 2B recorded on the second recording medium 32 has a relatively high relationship between the command current and the discharge flow rate at a relatively low first discharge pressure (for example, 8 MPa).
- the relationship between the command current and the discharge flow rate at the second discharge pressure (for example, 15 MPa) is included.
- the characteristic data recorded on each of the first recording medium 31 and the second recording medium 32 may be only the relationship between the command current and the discharge flow rate at one discharge pressure.
- the equipment unit 1A is mounted on, for example, a construction machine (such as a hydraulic excavator or a hydraulic crane) or an industrial machine. And the 1st apparatus 2A and the 2nd apparatus 2B are controlled by the control apparatus of those machines. For example, the control device sends a command current to the first device 2A and the second device 2B in accordance with the operation amount of the operation device operated by the user.
- a construction machine such as a hydraulic excavator or a hydraulic crane
- industrial machine such as a hydraulic excavator or a hydraulic crane
- the characteristic data of the first device 2A recorded on the first recording medium 31 and the characteristic data of the second device 2B recorded on the second recording medium 32 are read by a bar code reader and input to the above-described machine control device. Is done.
- the control device electronically calibrates variations in characteristics of the first device 2A and the second device 2B. For example, the control device adjusts the command current to be supplied to the first device 2A and the second device 2B so that a set discharge flow rate corresponding to the operation amount of the operation device operated by the user is obtained.
- the characteristic data of the first device 2A is recorded on the first recording medium 31, and the characteristic data of the second device 2B is recorded on the second recording medium 32. Therefore, the characteristic data of the first device 2A and the second device 2B can be directly read. Moreover, since the first recording medium 31 and the second recording medium 32 are attached to one side surface of the casing of the first device 2A so as to be adjacent to each other, the characteristic data of the first device 2A and the second device 2B are stored for a short time. Can be read efficiently.
- the characteristic data recorded on each recording medium (31 or 32) is the relationship between the command current and the discharge flow rate at two different discharge pressures, so that it corresponds to the discharge pressure of the pump. Calibration can also be performed.
- FIG. 3 shows a device unit 1B according to the second embodiment of the present invention.
- the device unit 1B includes a first device 4A and a second device 4B that are connected to each other.
- the device unit 1B may include three or more devices connected to each other.
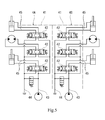
- each of the first device 4A and the second device 4B is a multi-control valve that includes a plurality of spools 42 that change the passage flow rate according to the command current, as shown in FIG.
- each of the first device 4A and the second device 4B includes a casing 41 that is independent of each other.
- Each casing 41 is, for example, a hexahedron having six side surfaces.
- One side surface of the casing 41 of the first device 4A and one side surface of the casing 21 of the second device 4B are in surface contact.
- each spool 42 controls the amount of hydraulic fluid supplied from the hydraulic pump to the hydraulic actuator and the amount of hydraulic fluid discharged from the hydraulic actuator to the tank.
- the hydraulic actuator may be a hydraulic cylinder or a hydraulic pump.
- Each drive mechanism pair operates the corresponding spool 42 in one direction and the other direction according to the command current.
- Each drive mechanism pair may be an electromagnetic proportional valve that outputs a secondary pressure as a pilot pressure to the corresponding spool 42.
- each drive mechanism pair may be a solenoid that presses the corresponding spool 42.
- a pump port 43 and a tank port 44 are provided on one side surface (lower surface in FIG. 3) of the casing 41 of each of the first device 4A and the second device 4B.
- a plurality of actuator ports 45 are provided on two side surfaces (the right surface and the left surface in FIG. 3) of the casing 41 of each of the first device 4A and the second device 4B.
- the number of hydraulic circuits and actuator ports 45 shown in FIG. 5 can be changed as appropriate.
- a first recording medium 33 and a second recording medium 34 are attached to one side surface (front surface in FIG. 1) of the casing 41 of the first device 4A so as to be adjacent to each other.
- the first recording medium 33 and the second recording medium 34 may be attached adjacent to one side surface of the casing 41 of the second device 4B.
- the characteristic data of the first device 4A is recorded on the first recording medium 33 with a barcode
- the characteristic data of the second device 4B is recorded on the second recording medium 34 with a barcode
- the barcode is a matrix type two-dimensional code (QR code (registered trademark)).
- the first recording medium 33 and the second recording medium 34 are separate. However, the first recording medium 33 and the second recording medium 34 may be integrated. In this case, a single object can be used as the two recording media 33 and 34.
- the attachment of the first recording medium 33 and the second recording medium 34 to the casing 41 may be, for example, affixed with an adhesive or a double-sided tape, or may be screwed.
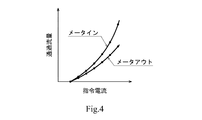
- Each of the characteristic data of the first device 4A and the characteristic data of the second device 4B described above is a relationship between the command current and the passing flow rate in each spool 42 as shown in FIG.
- the relationship between the command current and the passing flow rate exists for each operation direction of the spool 42.
- the characteristic data is discrete data as indicated by a plurality of points in FIG. 4 and is measured at the factory before shipping the corresponding device (4A or 4B). In addition, when the device is repaired (for example, part replacement), the characteristic data is also remeasured.
- the date when the characteristic data of the corresponding device (4A or 4B) is measured is also recorded in a visible manner. Further, identification data (individual product number) of the corresponding device (4A or 4B) is also recorded in each of the first recording medium 33 and the second recording medium 34.
- the equipment unit 1B is mounted on, for example, a construction machine (such as a hydraulic excavator or a hydraulic crane) or an industrial machine. And the 1st apparatus 4A and the 2nd apparatus 4B are controlled by the control apparatus of those machines. For example, the control device sends a command current to the drive mechanism pair of the first device 4A and the drive mechanism pair of the second device 4B in accordance with the operation amount of the operation device operated by the user.
- the characteristic data of the first device 4A recorded on the first recording medium 33 and the characteristic data of the second device 4B recorded on the second recording medium 34 are read by a bar code reader and input to the above-described machine control device. Is done.
- the control device electronically calibrates variations in characteristics of the first device 4A and the second device 4B. For example, the control device feeds the drive mechanism pair of the first device 4A and the drive mechanism pair of the second device 4B so that a set passage flow rate corresponding to the operation amount of the operation device operated by the user is obtained. Adjust the command current.
- the characteristic data of the first device 4A is recorded on the first recording medium 33
- the characteristic data of the second device 4B is recorded on the second recording medium 34. Therefore, the characteristic data of the first device 4A and the second device 4B can be directly read. Moreover, since the first recording medium 33 and the second recording medium 34 are attached adjacent to one side surface of the casing of the first device 4A, the characteristic data of the first device 4A and the second device 4B can be obtained for a short time. Can be read efficiently.
- the storage destination IP address of the characteristic data of the first device 2A is recorded in the first recording medium 31, and the storage destination IP address of the characteristic data of the second device 2B is stored in the second recording medium 32. It is also possible to record. In this case, recording of the storage destination IP address on each recording medium does not have to be performed by a barcode, and may be performed by printing, for example.
- the characteristic data of each device can be read via the Internet. Furthermore, with this configuration, a large amount of characteristic data can be stored in the server or terminal, so that variations in device characteristics can be accurately calibrated. Note that the modification of recording the characteristic data storage destination IP address on the recording medium is also applicable to the second embodiment.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- Mechanical Engineering (AREA)
- General Physics & Mathematics (AREA)
- Theoretical Computer Science (AREA)
- Electromagnetism (AREA)
- Health & Medical Sciences (AREA)
- General Health & Medical Sciences (AREA)
- Toxicology (AREA)
- Artificial Intelligence (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Automation & Control Theory (AREA)
- Computer Hardware Design (AREA)
- Valve Housings (AREA)
- Fluid-Pressure Circuits (AREA)
- Management, Administration, Business Operations System, And Electronic Commerce (AREA)
- Control Of Positive-Displacement Pumps (AREA)
Abstract
機器ユニットは、互いに連結された、独立したケーシングをそれぞれ含む2つ以上の機器を備え、2つ以上の機器のうちの1つの機器のケーシングの1つの側面に、2つ以上の機器の特性データまたは当該特性データの保存先IPアドレスをそれぞれ記録した2つ以上の記録媒体が互いに隣接して取り付けられている。
Description
本発明は、互いに連結された2つ以上の機器を含む機器ユニットに関する。
例えば、特許文献1の図3には、1つのケーシングに3つの比例電磁弁が組み込まれた機器(弁装置)が開示されている。この機器では、ケーシングの側面に、3つの比例電磁弁の特性データ(指令電流と出力圧との関係)をバーコードにより記録した記録媒体が取り付けられている。
このような構成であれば、比例電磁弁の特性にばらつきがあっても、記録媒体に記録された特性データを読取装置(例えば、バーコードリーダ)で読み取り、それらの比例電磁弁へ指令電流を送給する制御装置へ読み取った特性データを入力することで、比例電磁弁の特性のばらつきを電子的にキャリブレーションすることができる。
しかしながら、2つ以上の機器を互いに連結して機器ユニットを構成する場合は、各機器の特性データを記録した記録媒体をどのように取り付けるべきかが問題となる。なお、記録媒体に特性データを記録する代わりに、特性データをサーバや端末などに保存し、その保存先IP(Internet Protocol)アドレスを記録媒体に記録することも可能である。
そこで、本発明は、2つ以上の機器の特性データを効率的に読み込むことができる機器ユニットを提供することを目的とする。
前記課題を解決するために、本発明の機器ユニットは、互いに連結された、独立したケーシングをそれぞれ含む2つ以上の機器を備え、前記2つ以上の機器のうちの1つの機器のケーシングの1つの側面に、前記2つ以上の機器の特性データまたは当該特性データの保存先IPアドレスをそれぞれ記録した2つ以上の記録媒体が互いに隣接して取り付けられている、ことを特徴とする。
上記の構成によれば、各記録媒体に対応する機器の特性データが記録されている場合は直接的に、各記録媒体に対応する機器の特性データの保存先IPアドレスが記録されている場合はインターネットを介して、2つ以上の機器の特性データを読み込むことができる。しかも、それらの記録媒体は1つの機器のケーシングの1つの側面に互いに隣接して取り付けられているので、2つ以上の機器の特性データを短時間で効率的に読み込むことができる。
例えば、前記2つ以上の機器のそれぞれは、指令電流に応じて吐出流量が変化するポンプであり、前記機器の特性データは、特定の吐出圧での前記指令電流と前記吐出流量との関係であってもよい。
前記特定の吐出圧は、互いに異なる2つの吐出圧であってもよい。この構成によれば、ポンプの吐出圧に応じたキャリブレーションも行うことができる。
あるいは、前記2つ以上の機器のそれぞれは、指令電流に応じて通過流量を変更する複数のスプールを内蔵するマルチコントロールバルブであり、前記機器の特性データは、前記複数のスプールのそれぞれにおける前記指令電流と前記通過流量との関係であってもよい。
前記2つ以上の記録媒体のそれぞれには、対応する前記機器の特性データを計測した日付も目視可能に記録されていてもよい。機器が修理(例えば、部品交換など)された際には特性データも再計測される。その再計測された日付は対応する記録媒体に目視可能に記録されているので、使用者は、記録媒体を見れば機器の修理来歴を把握することができる。従って、現場でのメンテナンス性が向上する。
前記2つ以上の記録媒体は、一体となっていてもよい。この構成によれば、2つ以上の記録媒体として単一物を用いることができる。
本発明によれば、2つ以上の機器の特性データを効率的に読み込むことができる。
(第1実施形態)
図1に、本発明の第1実施形態に係る機器ユニット1Aを示す。この機器ユニット1Aは、互いに連結された第1機器2Aおよび第2機器2Bを含む。ただし、機器ユニット1Aは、互いに連結された3つ以上の機器を含んでもよい。
図1に、本発明の第1実施形態に係る機器ユニット1Aを示す。この機器ユニット1Aは、互いに連結された第1機器2Aおよび第2機器2Bを含む。ただし、機器ユニット1Aは、互いに連結された3つ以上の機器を含んでもよい。
本実施形態では、第1機器2Aおよび第2機器2Bのそれぞれが、指令電流に応じて吐出流量が変化する可変容量型の斜板ポンプである。ただし、第1機器2Aおよび第2機器2Bのそれぞれは斜軸ポンプであってもよい。
具体的に、第1機器2Aおよび第2機器2Bのそれぞれは、互いに独立したケーシング21を含む。各ケーシング21は、例えば6つの側面を有する六面体である。第1機器2Aのケーシング21の1つの側面と第2機器2Bのケーシング21の1つの側面とが中間ケーシング25を挟んで対向している。
図示は省略するが、第1機器2Aのケーシング21内には、回転軸22に固定されたシリンダと、このシリンダに保持された複数のピストンと、各ピストンの先端に取り付けられたシュートと摺動する斜板が配置されている。
同様に、第2機器2Bのケーシング21内には、回転軸(図示せず)に固定されたシリンダと、このシリンダに保持された複数のピストンと、各ピストンの先端に取り付けられたシュートと摺動する斜板が配置されている。第2機器2Bの回転軸は、中間ケーシング25内で第1機器2Aの回転軸22と連結されている。
第1機器2Aのケーシング21および第2機器2Bのケーシング21のそれぞれには、回転軸の中心線と直交する面に対する斜板の角度を指令電流に応じて変更するサーボ機構が組み込まれている。例えば、サーボ機構は、斜板と連結されたサーボピストンに作用する油圧を電気的に変更するように構成されてもよいし、斜板と連結された電動アクチュエータを含んでもよい。
第1機器2Aのケーシング21の1つの側面には、第1記録媒体31および第2記録媒体32が互いに隣接して取り付けられている。ただし、第1記録媒体31および第2記録媒体32は、第2機器2Bのケーシング21の1つの側面に互いに隣接して取り付けられてもよい。
本実施形態では、第1記録媒体31に第1機器2Aの特性データがバーコードにより記録され、第2記録媒体32に第2機器2Bの特性データがバーコードにより記録されている。例えば、バーコードは、マトリクス型の二次元コード(QRコード(登録商標))である。
また、本実施形態では、第1記録媒体31と第2記録媒体32とが別体となっている。ただし、第1記録媒体31と第2記録媒体32とが一体となってもよい。この場合には、2つの記録媒体31,32として単一物を用いることができる。
第1記録媒体31および第2記録媒体32のケーシング21への取り付けは、例えば、接着剤や両面テープによる貼り付けであってもよいし、ビス止めであってもよい。
上述した第1機器2Aの特性データおよび第2機器2Bの特性データのそれぞれは、図2に示すように、特定の吐出圧での指令電流と吐出流量との関係である。特性データは、図2中に複数の点で示すように離散的なデータであり、対応する機器(2Aまたは2B)の出荷前に工場で計測される。また、機器が修理(例えば、部品交換など)された際には特性データも再計測される。
第1記録媒体31および第2記録媒体32のそれぞれには、対応する機器(2Aまたは2B)の特性データを計測した日付も目視可能に記録されている。また、第1記録媒体31および第2記録媒体32のそれぞれには、対応する機器(2Aまたは2B)の識別データ(個別製品番号)も記録されている。
第1機器2Aおよび第2機器2Bであるポンプの特性は、ポンプの吐出圧に応じて変化する。そこで、本実施形態では、上述した特定の吐出圧が互いに異なる2つの吐出圧である。すなわち、第1記録媒体31に記録された第1機器2Aの特性データは、相対的に低い第1吐出圧(例えば、8MPa)での指令電流と吐出流量との関係と、相対的に高い第2吐出圧(例えば、15MPa)での指令電流と吐出流量との関係を含む。同様に、第2記録媒体32に記録された第2機器2Bの特性データは、相対的に低い第1吐出圧(例えば、8MPa)での指令電流と吐出流量との関係と、相対的に高い第2吐出圧(例えば、15MPa)での指令電流と吐出流量との関係を含む。ただし、第1記録媒体31および第2記録媒体32のそれぞれに記録される特性データは、1つの吐出圧での指令電流と吐出流量との関係だけであってもよい。
機器ユニット1Aは、例えば、建設機械(油圧ショベルや油圧クレーンなど)または産業機械に搭載される。そして、第1機器2Aおよび第2機器2Bは、それらの機械の制御装置により制御される。例えば、制御装置は、使用者により操作される操作装置の操作量に応じて、第1機器2Aおよび第2機器2Bへ指令電流を送給する。
第1記録媒体31に記録された第1機器2Aの特性データおよび第2記録媒体32に記録された第2機器2Bの特性データは、バーコードリーダで読み取られて上述した機械の制御装置へ入力される。制御装置は、第1機器2Aおよび第2機器2Bの特性のばらつきを電子的にキャリブレーションする。例えば、制御装置は、使用者により操作される操作装置の操作量に対応する設定吐出流量が得られるように、第1機器2Aおよび第2機器2Bへ送給する指令電流を調整する。
以上説明したように、本実施形態の機器ユニット1Aでは、第1記録媒体31に第1機器2Aの特性データが記録され、第2記録媒体32に第2機器2Bの特性データが記録されているので、第1機器2Aおよび第2機器2Bの特性データを直接的に読み込むことができる。しかも、第1記録媒体31および第2記録媒体32は第1機器2Aのケーシングの1つの側面に互いに隣接して取り付けられているので、第1機器2Aおよび第2機器2Bの特性データを短時間で効率的に読み込むことができる。
また、本実施形態では、各記録媒体(31または32)に記録された特性データが、互いに異なる2つの吐出圧での指令電流と吐出流量との関係であるので、ポンプの吐出圧に応じたキャリブレーションも行うことができる。
さらに、本実施形態では、各記録媒体(31または32)に対応する機器(2Aまたは2B)の特性データを計測した日付が目視可能に記録されているので、使用者は、記録媒体を見れば機器の修理来歴を把握することができる。従って、現場でのメンテナンス性が向上する。
(第2実施形態)
図3に、本発明の第2実施形態に係る機器ユニット1Bを示す。この機器ユニット1Bは、互いに連結された第1機器4Aおよび第2機器4Bを含む。ただし、機器ユニット1Bは、互いに連結された3つ以上の機器を含んでもよい。
図3に、本発明の第2実施形態に係る機器ユニット1Bを示す。この機器ユニット1Bは、互いに連結された第1機器4Aおよび第2機器4Bを含む。ただし、機器ユニット1Bは、互いに連結された3つ以上の機器を含んでもよい。
本実施形態では、第1機器4Aおよび第2機器4Bのそれぞれが、図5に示すように、指令電流に応じて通過流量を変更する複数のスプール42を内蔵するマルチコントロールバルブである。
具体的に、第1機器4Aおよび第2機器4Bのそれぞれは、互いに独立したケーシング41を含む。各ケーシング41は、例えば6つの側面を有する六面体である。第1機器4Aのケーシング41の1つの側面と第2機器4Bのケーシング21の1つの側面とが面接触している。
図5に示すように、各スプール42は、液圧ポンプから液圧アクチュエータへの作動液の供給量および液圧アクチュエータからタンクへの作動液の排出量を制御するものである。液圧アクチュエータは、液圧シリンダであってもよいし液圧ポンプであってもよい。
第1機器4Aおよび第2機器4Bのそれぞれのケーシング41には、スプール42と同数の駆動機構対が組み込まれている。各駆動機構対は、指令電流に応じて対応するスプール42を一方向および他方向に作動させる。各駆動機構対のそれぞれは、対応するスプール42へパイロット圧として二次圧を出力する電磁比例弁であってもよい。あるいは、各駆動機構対のそれぞれは、対応するスプール42を押圧するソレノイドであってもよい。
第1機器4Aおよび第2機器4Bのそれぞれのケーシング41の1つの側面(図3では下面)には、ポンプポート43およびタンクポート44(図5参照)が設けられている。また、第1機器4Aおよび第2機器4Bのそれぞれのケーシング41の2つの側面(図3では右面および左面)には、複数のアクチュエータポート45が設けられている。ただし、図5に記載した液圧回路およびアクチュエータポート45の数は適宜変更可能である。
図3に示すように、第1機器4Aのケーシング41の1つの側面(図1では前面)には、第1記録媒体33および第2記録媒体34が互いに隣接して取り付けられている。ただし、第1記録媒体33および第2記録媒体34は、第2機器4Bのケーシング41の1つの側面に互いに隣接して取り付けられてもよい。
本実施形態では、第1記録媒体33に第1機器4Aの特性データがバーコードにより記録され、第2記録媒体34に第2機器4Bの特性データがバーコードにより記録されている。例えば、バーコードは、マトリクス型の二次元コード(QRコード(登録商標))である。
また、本実施形態では、第1記録媒体33と第2記録媒体34とが別体となっている。ただし、第1記録媒体33と第2記録媒体34とが一体となってもよい。この場合には、2つの記録媒体33,34として単一物を用いることができる。
第1記録媒体33および第2記録媒体34のケーシング41への取り付けは、例えば、接着剤や両面テープによる貼り付けであってもよいし、ビス止めであってもよい。
上述した第1機器4Aの特性データおよび第2機器4Bの特性データのそれぞれは、図4に示すように、各スプール42における指令電流と通過流量との関係である。この指令電流と通過流量との関係は、スプール42の作動方向ごとに存在する。また、通過流量は、メータインの通過流量とメータアウトの通過流量の2種類である。
特性データは、図4中に複数の点で示すように離散的なデータであり、対応する機器(4Aまたは4B)の出荷前に工場で計測される。また、機器が修理(例えば、部品交換など)された際には特性データも再計測される。
第1記録媒体33および第2記録媒体34のそれぞれには、対応する機器(4Aまたは4B)の特性データを計測した日付も目視可能に記録されている。また、第1記録媒体33および第2記録媒体34のそれぞれには、対応する機器(4Aまたは4B)の識別データ(個別製品番号)も記録されている。
機器ユニット1Bは、例えば、建設機械(油圧ショベルや油圧クレーンなど)または産業機械に搭載される。そして、第1機器4Aおよび第2機器4Bは、それらの機械の制御装置により制御される。例えば、制御装置は、使用者により操作される操作装置の操作量に応じて、第1機器4Aの駆動機構対および第2機器4Bの駆動機構対へ指令電流を送給する。
第1記録媒体33に記録された第1機器4Aの特性データおよび第2記録媒体34に記録された第2機器4Bの特性データは、バーコードリーダで読み取られて上述した機械の制御装置へ入力される。制御装置は、第1機器4Aおよび第2機器4Bの特性のばらつきを電子的にキャリブレーションする。例えば、制御装置は、使用者により操作される操作装置の操作量に対応する設定通過流量が得られるように、第1機器4Aの駆動機構対および第2機器4Bの駆動機構対へ送給する指令電流を調整する。
以上説明したように、本実施形態の機器ユニット1Bでは、第1記録媒体33に第1機器4Aの特性データが記録され、第2記録媒体34に第2機器4Bの特性データが記録されているので、第1機器4Aおよび第2機器4Bの特性データを直接的に読み込むことができる。しかも、第1記録媒体33および第2記録媒体34は第1機器4Aのケーシングの1つの側面に互いに隣接して取り付けられているので、第1機器4Aおよび第2機器4Bの特性データを短時間で効率的に読み込むことができる。
さらに、本実施形態では、各記録媒体(33または34)に対応する機器(4Aまたは4B)の特性データを計測した日付が目視可能に記録されているので、使用者は、記録媒体を見れば機器の修理来歴を把握することができる。従って、現場でのメンテナンス性が向上する。
(その他の実施形態)
本発明は上述した実施形態に限定されるものではなく、本発明の要旨を逸脱しない範囲で種々の変形が可能である。
本発明は上述した実施形態に限定されるものではなく、本発明の要旨を逸脱しない範囲で種々の変形が可能である。
例えば、第1実施形態においては、各記録媒体(31または32)に対応する機器(2Aまたは2B)の特性データを記録する代わりに、第1機器2Aの特性データおよび第2機器2Bの特性データをサーバや端末などに保存し、第1機器2Aの特性データの保存先IPアドレスを第1記録媒体31に記録するとともに第2機器2Bの特性データの保存先IPアドレスを第2記録媒体32に記録することも可能である。この場合、各記録媒体への保存先IPアドレスの記録は、バーコードにより行われる必要はなく、例えば印字により行われてもよい。
上記の構成であれば、インターネットを介して各機器の特性データを読み込むことができる。さらに、この構成であれば、サーバまたは端末に大量の特性データが保存できるので、機器の特性のばらつきを正確にキャリブレーションすることができる。なお、記録媒体に特性データの保存先IPアドレスを記録するという変形は、第2実施形態でも適用可能である。
1A,1B 機器ユニット
2A,2B 機器
21 ケーシング
4A,4B 機器
41 ケーシング
31~34 記録媒体
2A,2B 機器
21 ケーシング
4A,4B 機器
41 ケーシング
31~34 記録媒体
Claims (6)
- 互いに連結された、独立したケーシングをそれぞれ含む2つ以上の機器を備え、
前記2つ以上の機器のうちの1つの機器のケーシングの1つの側面に、前記2つ以上の機器の特性データまたは当該特性データの保存先IPアドレスをそれぞれ記録した2つ以上の記録媒体が互いに隣接して取り付けられている、機器ユニット。 - 前記2つ以上の機器のそれぞれは、指令電流に応じて吐出流量が変化するポンプであり、
前記機器の特性データは、特定の吐出圧での前記指令電流と前記吐出流量との関係である、請求項1に記載の機器ユニット。 - 前記特定の吐出圧は、互いに異なる2つの吐出圧である、請求項2に記載の機器ユニット。
- 前記2つ以上の機器のそれぞれは、指令電流に応じて通過流量を変更する複数のスプールを内蔵するマルチコントロールバルブであり、
前記機器の特性データは、前記複数のスプールのそれぞれにおける前記指令電流と前記通過流量との関係である、請求項1に記載の機器ユニット。 - 前記2つ以上の記録媒体のそれぞれには、対応する前記機器の特性データを計測した日付も目視可能に記録されている、請求項1~4の何れか一項に記載の機器ユニット。
- 前記2つ以上の記録媒体は、一体となっている、請求項1~5の何れか一項に記載の機器ユニット。
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201980027106.1A CN111989515B (zh) | 2018-06-01 | 2019-05-28 | 机器单元 |
| US15/734,161 US20210216051A1 (en) | 2018-06-01 | 2019-05-28 | Apparatus unit |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2018-106042 | 2018-06-01 | ||
| JP2018106042A JP7037440B2 (ja) | 2018-06-01 | 2018-06-01 | 機器ユニット |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2019230681A1 true WO2019230681A1 (ja) | 2019-12-05 |
Family
ID=68696975
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2019/020995 Ceased WO2019230681A1 (ja) | 2018-06-01 | 2019-05-28 | 機器ユニット |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US20210216051A1 (ja) |
| JP (1) | JP7037440B2 (ja) |
| CN (1) | CN111989515B (ja) |
| WO (1) | WO2019230681A1 (ja) |
Families Citing this family (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7798616B2 (ja) * | 2022-03-10 | 2026-01-14 | 川崎重工業株式会社 | コントローラおよびキャリブレーションシステム |
| JP2022140429A (ja) * | 2022-03-28 | 2022-09-26 | 川崎重工業株式会社 | プログラム |
| JP2024071104A (ja) * | 2022-11-14 | 2024-05-24 | 川崎重工業株式会社 | ポンプ装置 |
| JP2024156272A (ja) * | 2023-04-24 | 2024-11-06 | 川崎重工業株式会社 | コントローラおよびポンプシステム |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002180897A (ja) * | 2000-12-13 | 2002-06-26 | Denso Corp | 内燃機関の調整方法 |
| JP2006114525A (ja) * | 2004-09-15 | 2006-04-27 | Nachi Fujikoshi Corp | ソレノイド部材の特性補正装置及びソレノイド部材 |
Family Cites Families (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6097171A (en) * | 1998-01-30 | 2000-08-01 | A. O. Smith Corporation | Method and apparatus for controlling an induction motor |
| DE10153625A1 (de) * | 2000-11-02 | 2002-07-11 | Denso Corp | Vorrichtung zur Steuerung einer Brennkraftmaschine, diese Maschinensteuervorrichtung verwendendes Datenkommunikationssystem, Steuerdatenbereitstellungssystem für ein Maschinensteuersystem, zugehöriges Maschineneinstellverfahren und Einspritzeinrichtungsdatenlesevorrichtung |
| US6986646B2 (en) * | 2002-04-12 | 2006-01-17 | Caterpillar Inc. | Electronic trim for a variable delivery pump in a hydraulic system for an engine |
| JP2006083959A (ja) * | 2004-09-16 | 2006-03-30 | Fujikin Inc | センサ付き継手部材 |
| US8321114B2 (en) * | 2010-05-20 | 2012-11-27 | Komatsu Ltd. | Work vehicle and work vehicle control method |
| DE102012105951A1 (de) * | 2012-03-30 | 2013-10-02 | Pfeiffer Vacuum Gmbh | Pumpensystem zur Evakuierung von Gas aus einer Mehrzahl von Kammern sowie Verfahren zur Steuerung des Pumpensystems |
| TWI496096B (zh) * | 2012-05-31 | 2015-08-11 | Toshiba Global Commerce Solutions Holdings Corp | 在一物品區域中管理複數物品的系統、方法、與儲放單元 |
| EP2923283B1 (en) * | 2012-11-26 | 2020-05-27 | Fisher & Paykel Healthcare Limited | Transfer of breathing assistance apparatus data |
| US10316849B2 (en) * | 2014-10-15 | 2019-06-11 | Grundfos Holding A/S | Method and system for detection of faults in pump assembly via handheld communication device |
| US11085440B2 (en) * | 2015-09-02 | 2021-08-10 | Project Phoenix, LLC | System to pump fluid and control thereof |
| CA2930323C (en) * | 2016-05-17 | 2023-11-14 | Op-Hygiene Ip Gmbh | Superimposed qr code for dispenser and replaceable reservoir |
| CN207246512U (zh) * | 2017-09-15 | 2018-04-17 | 广州智特信息科技有限公司 | 带电子信息标签的角阀 |
-
2018
- 2018-06-01 JP JP2018106042A patent/JP7037440B2/ja active Active
-
2019
- 2019-05-28 WO PCT/JP2019/020995 patent/WO2019230681A1/ja not_active Ceased
- 2019-05-28 US US15/734,161 patent/US20210216051A1/en not_active Abandoned
- 2019-05-28 CN CN201980027106.1A patent/CN111989515B/zh active Active
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002180897A (ja) * | 2000-12-13 | 2002-06-26 | Denso Corp | 内燃機関の調整方法 |
| JP2006114525A (ja) * | 2004-09-15 | 2006-04-27 | Nachi Fujikoshi Corp | ソレノイド部材の特性補正装置及びソレノイド部材 |
Also Published As
| Publication number | Publication date |
|---|---|
| CN111989515B (zh) | 2022-09-16 |
| JP2019210974A (ja) | 2019-12-12 |
| JP7037440B2 (ja) | 2022-03-16 |
| CN111989515A (zh) | 2020-11-24 |
| US20210216051A1 (en) | 2021-07-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7037440B2 (ja) | 機器ユニット | |
| US20030125840A1 (en) | System and method for controlling hydraulic flow | |
| US20230136445A1 (en) | Servoless motor | |
| CN105840566B (zh) | 用于为至少两个液压负载供应压力介质的液压控制装置 | |
| EP3663580B1 (en) | Hydraulic drive apparatus | |
| JP2015105676A5 (ja) | ||
| WO2019087565A1 (ja) | 油圧装置 | |
| KR20190014062A (ko) | 유량 제어 밸브 장치 | |
| US10443629B2 (en) | Operation device and hydraulic system | |
| US12196228B2 (en) | Electro-hydraulic power unit with variable output flow | |
| WO2019044616A1 (ja) | 電磁弁識別装置、及びそれを備える制御ユニット | |
| KR102941468B1 (ko) | 액추에이터 제어 장치 | |
| JP4198115B2 (ja) | サーボ・弁制御装置 | |
| JP7798616B2 (ja) | コントローラおよびキャリブレーションシステム | |
| JP2013019425A (ja) | 液圧装置 | |
| JP2024065399A (ja) | 液圧ポンプの性能低下検知システム | |
| CN118836146A (zh) | 控制器及泵系统 | |
| CN103939407B (zh) | 多流量控制阀、底盘支腿液控系统及起重机 | |
| US4561470A (en) | Servo valve control device | |
| US8096228B1 (en) | Bent axis dual yoke hydromodule | |
| CN221220763U (zh) | 泵装置 | |
| FI94662C (fi) | Sovitelma kallioporakoneen puomin toimisylintereiden ohjaamiseksi | |
| Hanson | Selecting Proportional Valves and High Response Valves g p | |
| Backé et al. | Fluidpower Actuators | |
| JP2024035295A (ja) | 液圧ポンプの性能低下検知システム |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 19812178 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 19812178 Country of ref document: EP Kind code of ref document: A1 |