EP3971934B1 - Dispositif pour le contrôle d'un microcontact dans un appareil de connexion électrique - Google Patents
Dispositif pour le contrôle d'un microcontact dans un appareil de connexion électrique Download PDFInfo
- Publication number
- EP3971934B1 EP3971934B1 EP21181668.1A EP21181668A EP3971934B1 EP 3971934 B1 EP3971934 B1 EP 3971934B1 EP 21181668 A EP21181668 A EP 21181668A EP 3971934 B1 EP3971934 B1 EP 3971934B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- actuator
- mobile part
- elastic blade
- movable member
- curved portion
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01H—ELECTRIC SWITCHES; RELAYS; SELECTORS; EMERGENCY PROTECTIVE DEVICES
- H01H71/00—Details of the protective switches or relays covered by groups H01H73/00 - H01H83/00
- H01H71/10—Operating or release mechanisms
- H01H71/12—Automatic release mechanisms with or without manual release
- H01H71/46—Automatic release mechanisms with or without manual release having means for operating auxiliary contacts additional to the main contacts
- H01H71/465—Self-contained, easily replaceable microswitches
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01H—ELECTRIC SWITCHES; RELAYS; SELECTORS; EMERGENCY PROTECTIVE DEVICES
- H01H3/00—Mechanisms for operating contacts
- H01H3/32—Driving mechanisms, i.e. for transmitting driving force to the contacts
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01H—ELECTRIC SWITCHES; RELAYS; SELECTORS; EMERGENCY PROTECTIVE DEVICES
- H01H3/00—Mechanisms for operating contacts
- H01H3/32—Driving mechanisms, i.e. for transmitting driving force to the contacts
- H01H3/42—Driving mechanisms, i.e. for transmitting driving force to the contacts using cam or eccentric
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01H—ELECTRIC SWITCHES; RELAYS; SELECTORS; EMERGENCY PROTECTIVE DEVICES
- H01H9/00—Details of switching devices, not covered by groups H01H1/00 - H01H7/00
- H01H9/0066—Auxiliary contact devices
Definitions
- the present disclosure relates to the field of electrical connection devices intended to be installed on a medium or high voltage power line. More specifically, the present invention relates to a device for interaction with a microcontact of an electrical connection device.
- Switches including switches, circuit breakers or disconnectors.
- Such devices include, among others, main electrical contacts actuated to break or make the current flowing through the line.
- Auxiliary electrical contacts may be added to provide information on the position of the main contacts.
- An auxiliary electrical contact is in particular a microcontact.
- the microcontact comprises a movable member for opening and closing a set of internal contacts. Actuation of the movable member generates the permutation of the set of internal contacts.
- an actuator connected to the main contacts by a kinematic chain, acts on the moving part of the microswitch.
- the permutation of the set of internal contacts is then representative of the movement of the main contacts.
- the microswitch can for example be connected to a management system to notify the position of the main contacts.
- Standards such as EDF HN 64-S-58 and IEC 62271-103, define limits in the synchronism between the change of state of the main contacts and that of the auxiliary contacts.
- inappropriate or untimely transient movements such as play catch-ups or elastic deformations, may occur in the kinematic chain. These movements can influence the permutation of the microswitch, leading, in certain cases of design of the kinematic chain, to not respecting the synchronism limits defined by these standards. It then appeared the need to artificially maintain the position of the moving part of the microswitch during the permutation.
- the present disclosure aims to control the permutation of the microswitch by acting in direct proximity to the microswitch, in order to improve the transmission of the information provided in an economical and simple to implement manner.
- the document EP 3 640 965 A1 describes a device for interacting with a microcontact according to the preamble of claim 1.
- the transition of the moving member to the rest position can be delayed by the separation of the moving member and the actuator.
- the transmission time of the information provided by the microcontact can be adapted.
- a set of auxiliary electrical contacts comprising a plurality of devices as described above, and a shaft rotationally securing the actuators of each device.
- the shaft is connected by gear to a main contact operating member on an electrical line.
- an electrical connection apparatus comprising an assembly as described above.
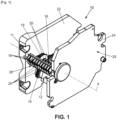
- FIG. 1 schematically illustrates a control mechanism 10 for an electrical connection apparatus located on a medium voltage or high voltage power line.
- the terms “medium voltage” and “high voltage” are used in their usual meaning, namely that the term “medium voltage” designates a voltage which is greater than 1,000 volts in alternating current and 1,500 volts in direct current but which does not exceed 52,000 volts in alternating current and 75,000 volts in direct current, while the term “high voltage” designates a voltage which is strictly greater than 52,000 volts in alternating current and 75,000 volts in direct current.
- such a control mechanism 10 comprises a main contact operating member 12 for controlling the opening or closing of an electrical line, as well as a system 14 for transmitting movement between the main contact operating member 12 and a set of auxiliary contacts 11.
- the auxiliary contact assembly 11 essentially comprises, as illustrated, a shaft 16, a plurality of microcontacts 18, and a support 25.
- the shaft 16 is connected to the transmission system 14 of the main contacts.
- the shaft 16 is rotatable about an axis A.
- the shaft 16 is intended to be driven in rotation about its axis A by the transmission system 14 during a movement of the operating member 12.
- the shaft 16 may in particular comprise a toothed wheel 19 to be driven by gears during the movement of the operating member 12.
- the shaft 16 is secured to a plurality of actuators 20, arranged regularly along the axis A.
- Each actuator 20 is arranged opposite one of the microcontacts 18, to mechanically actuate the microcontact 18 during rotation of the shaft 16 around the axis A.
- the support 25 makes it possible to mount the shaft 16 and the plurality of microcontacts 18 in the control mechanism 10.
- the support 25 here has a first plate 22 and a second plate 24, arranged facing the first plate 22.
- the shaft 16 is arranged between the plates 22, 24, in the transverse direction. Thus, the shaft 16 can be connected to the plates 22, 24, while being movable in rotation relative to the plates 22, 24.
- the support 25 also has a base 26 extending between the plates 22, 24.
- the base 26 comprises a plurality of cells 28, each cell 28 defining a housing 28 for one of the microcontacts 18.
- the device 30 comprises the microcontact 18, the actuator 20 and an elastic blade 32.
- the elastic blade 32 extends between the actuator 20 and the microcontact 18, to intervene in the actuation of the microcontact 18.
- the microswitch 18 essentially comprises a body 33 and a movable member 34 mounted on the body 33.
- the body 33 here has three blades 35, 36, 38, projecting from a housing 40 of the body 33.
- a first blade 35 defines a power supply terminal 35 of the microcontact 18, to be connected to a voltage or current source.
- a second blade 36 and a third blade 38 respectively define a normally open terminal 36 and a normally closed terminal 38 of the microcontact 18, to be connected to an electrical circuit.
- the housing 40 contains a set of internal contacts, to place the power supply terminal 35 in electrical contact with the normally open terminal 36 or the normally closed terminal 38 of the microcontact 18.
- a movement of the movable member 34 causes the set of internal contacts to be permuted.
- the movable member 34 here takes the form of a pallet 34.
- the pallet 34 interacts with a pusher 41, provided with a return spring, to define a rest position and an active position of the pallet 34. In the rest position, the pallet 34 does not exert any force on the pusher 41. Only the spring acts on the pusher 41.
- the power supply terminal 35 is in electrical contact with the normally closed terminal 38. In the active position, the pallet 34 is moved under the effect of a force exerted on the pallet 34, to press on the pusher 41, against the action of the return spring.
- the power supply terminal 35 is placed in electrical contact with the normally open terminal 36.
- the actuator 20 comprises a cam 42.
- the cam 42 takes the form of a projection extending radially outward relative to the axis A.
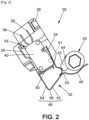
- the actuator 20 can adopt a first angular position, shown in figure 2 , in which the cam 42 presses on the movable member 34 of the microcontact 18, to maintain the movable member 34 in the active position.
- the first angular position may in particular correspond to the closing of the line and to a closed state of the electrical connection device.
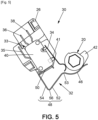
- a second angular position of the actuator 20 shown in figure 5 obtained by rotation around the axis A, the cam 42 is separated from the movable member 34 of the microcontact 18.
- the microcontact 18 is released from the actuator 20.
- the second angular position can correspond to the opening of the line and to an open state of the electrical connection device.
- the cam 42 may comprise a ramp 44.
- the ramp 44 extends on the side of the actuator 20 coming into contact with the movable member 34 during rotation of the actuator 20 from the second angular position to the first angular position.
- the force exerted by the cam 42 on the movable member 34 is progressive.
- the permutation from the rest position to the active position of the movable member 34 may be controlled by the ramp 44.
- the elastic blade 32 has, from one end in the vicinity of the actuator 20 to one end in the vicinity of the microcontact 18, a portion curved 46, a tab 48 and a fixing lug 50.
- the elastic blade 32 intervenes in the actuation of the movable member 34 of the microswitch 18 during the rotation of the actuator 20 from the first angular position to the second angular position.
- the permutation of the active position to the rest position of the movable member 34 can be controlled by the elastic blade 32.
- the curved portion 46 extends around the axis A of the actuator 20.
- the curved portion 46 defines a concavity facing the axis A.
- the curved portion 46 can be elastically biased by the cam 42 of the actuator 20.
- the curved portion 46 extends over a portion of the arc of a circle traveled by the cam 42 during a rotation from one of the first and second angular positions to the other of the first and second angular positions of the actuator 20.
- the curved portion 46 is released from the cam 42 when the actuator 20 is in the first or second angular position.
- the free end of the curved portion 46 bears on the actuator 20.
- the curved portion 46 is bent between the free end and the tab 48. In this case, the bending makes it possible to gradually move the curved portion 46 away from the actuator 20 relative to the axis A, over the entire extent of the curved portion 46.
- the other end of the curved portion 46 is connected to the tab 48 by a joint 53.
- the joint 53 is arranged facing the movable member 34.
- the joint 53 is rounded.
- the joint 53 defines a convexity oriented towards the movable member 34.
- the joint 53 is intended to allow the passage of the movable member 34 during its movement towards the active position.
- straight lines D1 and D2 define the shape of the articulation 53.
- the straight line D1 is tangent to the arc of a circle traveled by the movable member 34 during the permutation between one of the active position and the rest position to the other of the rest position and the active position of the microswitch 18.
- the straight line D2 is tangent to the curved portion 46, in the vicinity of the tab 48.
- the two ends of the articulation 53 connect the straight lines D1 and D2 along a radius R. The shape of the articulation 53 thus makes it possible to prevent the movable member 34 from remaining blocked by the elastic blade 32.
- the tab 48 has a substantially “V” shape.
- a first branch 52 of the “V” extends from a vertex 56 of the “V” to the articulation 53.
- the first branch 52 extends in the extension of the articulation 53.
- the first branch 52 is intended to come into contact with the movable member 34.
- the first branch 52 blocks the passage of the movable member 34.
- the first branch 52 blocks the movable member 34 by exerting a force on the movable member 34.
- the force exerted generates a holding torque for the movable member 34, greater than a release torque for the movable member 34 generated by the action of the return spring on the pusher 41.
- the movable member 34 could be blocked by friction or attachment of the movable member 34 to the first branch 52.
- the first branch 52 here allows the movable member 34 to slide along the first branch 52.
- a second branch 54 of the “V” extends from the apex 56 to an end in the vicinity of the microcontact 18.
- the geometry of the tab 48 can allow the translation of the first branch 52 around the apex 56 connecting the two branches 52, 54.
- the translation allows the first branch 52 to be separated from the movable member 34.
- the “V” shape facilitates the manufacture of the elastic blade 32.
- the tab 48 can take any other shape to allow the first branch 52 to be moved for the passage of the movable member 34 between the active position and the rest position.
- the angle formed by the first and second branches 52, 54 can be more or less open.
- the apex 56 of the “V” can also be more or less rounded.
- the fixing lug 50 extends here along the body 33 of the microcontact 18.
- the fixing lug 50 is secured to the body 33 of the microcontact 18.
- the fixing lug 50 makes it possible to arrange the elastic blade 32 in the device 30. This prevents the elastic blade 32 from moving when the elastic blade 32 is stressed by the cam 42 of the actuator 20.
- the base 26 may be devoid of means for fixing the elastic blade 32, facilitating the manufacture of the base 26 and the assembly of the device 30.
- the actuator 20 can adopt a first and a second intermediate position, illustrated respectively by the figures 3 And 4 , moving from the first angular position to the second angular position.
- the first and second intermediate positions correspond to a position of the actuator 20 during opening of the electrical connection device.
- the second intermediate position is subsequent to the first intermediate position during the movement of the actuator 20, and is associated with the release of the microcontact 18 from the elastic blade 32.
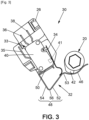
- the cam 42 of the actuator 20 comes into contact with the curved portion 46.
- the elastic blade 32 is not stressed by the cam 42 until the actuator 20 is in the first intermediate position.
- the end of the cam 42 is in the vicinity of the free end of the curved portion 46.
- the cam 42 presses on the curved portion 46.
- the actuator 20 can also adopt a third intermediate position, illustrated by the figure 6 , moving from the second angular position to the first angular position.
- the third intermediate position corresponds to a position of the actuator 20 in the process of closing the electrical connection device.
- the actuator 20 is in the first angular position, illustrated in figure 2 .
- the cam 42 of the actuator 20 acts on the movable member 34 of the microcontact 18 to maintain the movable member 34 in the active position.
- the power supply terminal 35 of the microcontact 18 is connected to the normally open terminal 36 of the microcontact 18.
- the current flowing through the microcontact 18 can for example inform that the line is in the closed position.
- the actuator 20 is driven to the second angular position, illustrated in figure 5 .
- the cam 42 of the actuator 20 releases the movable member 34.
- the elastic blade 32 holds the movable member 34 of the microswitch 18 in active position.
- the movable member 34 is held in active position. under the effect of the tab 48, in particular of the first branch 52 of the tab 48.
- the first branch 52 blocks the passage of the movable member 34.
- the cam 42 of the actuator 20 comes into contact with the curved portion 46 of the elastic blade 32, then exerts an increasing force on the curved portion 46.
- the force exerted on the curved portion 46 by the cam 42 causes the translation of the first branch 52 of the elastic blade 32.
- the force exerted by the cam 42 of the actuator 20 on the curved portion 46 decreases.
- the ramp 44 of the cam 42 gradually returns the curved portion 46 of the elastic blade 32 to the initial position of the figure 2 .
- the cam 42 of the actuator 20 is separated from the movable member 34 and from the elastic blade 32.
- the elastic blade 32 is in the initial position of the figure 2 .
- the movable member 34 of the microcontact 18 is in the rest position.
- the power supply terminal 35 of the microcontact 18 is connected to the normally closed terminal 38 of the microcontact 18.
- the current flowing through the microcontact 18 can for example inform that the line is in an open position.
- the actuator 20 is driven to the first angular position of the figure 2 .
- the cam 42 of the actuator 20 comes into contact with the curved portion 46 of the elastic blade 32, then exerts a force on the curved portion 46.
- the ramp 44 comes into contact with the movable member 34, to gradually push the movable contact 34 towards the active position.
- the movement of the movable member 34 brings the movable member 34 closer to the articulation 53 of the elastic blade 32.
- the articulation 53 allows the passage of the movable member 34.
- the movable member 34 can then come into contact with the first branch 52, then slide along the first branch 52.
- the second angular position of the actuator 20 can correspond to the grounding of the line.
- the device 30 can then provide information about the grounding of the line.
Landscapes
- Rotary Switch, Piano Key Switch, And Lever Switch (AREA)
- Push-Button Switches (AREA)
- Mechanisms For Operating Contacts (AREA)
Description
- La présente divulgation relève du domaine des appareils de connexion électrique destinés à être installés sur une ligne électrique moyenne ou haute tension. Plus précisément, la présente invention vise un dispositif d'interaction avec un microcontact d'un appareil de connexion électrique.
- Les lignes de moyenne et de haute tension sont couramment équipées d'appareils de connexion électrique, notamment des interrupteurs, des disjoncteurs ou des sectionneurs. De tels appareils comprennent, entre autres, des contacts électriques principaux actionnés pour couper ou établir le courant traversant la ligne. Des contacts électriques auxiliaires peuvent être ajoutés pour fournir une information sur la position des contacts principaux.
- Un contact électrique auxiliaire est notamment un microcontact. Le microcontact comprend un organe mobile pour ouvrir et fermer un jeu de contacts internes. L'actionnement de l'organe mobile génère la permutation du jeu de contacts internes.
- Généralement, un actionneur, relié aux contacts principaux par une chaine cinématique, agit sur l'organe mobile du microcontact. La permutation du jeu de contacts internes est alors représentative du mouvement des contacts principaux. Le microcontact peut par exemple être relié à un système de gestion pour notifier de la position des contacts principaux.
- Des normes, telles que les normes EDF HN 64-S-58 et CEI 62271-103, définissent des limites dans le synchronisme entre le changement d'état des contacts principaux et celui des contacts auxiliaires. Or, il peut se produire dans la chaine cinématique des mouvements transitoires inappropriés ou inopportuns, tels que des rattrapages de jeu ou des déformations élastiques. Ces mouvements peuvent influer sur la permutation du microcontact, conduisant, dans certains cas de conception de la chaîne cinématique, à ne pas respecter les limites de synchronisme définies par ces normes. Il est alors apparu le besoin de maintenir artificiellement la position de l'organe mobile du microcontact durant la permutation.
- Dans ces cas, il est connu de prévoir des composants pour empêcher artificiellement le mouvement des pièces de commande, c'est-à-dire des pièces de la chaîne cinématique entre les contacts principaux et les contacts auxiliaires, durant le mouvement de ces pièces.
- Cependant, ces solutions peuvent présenter une certaine complexité de mise en oeuvre, et augmenter l'encombrement de la chaine cinématique.
- La présente divulgation vise à contrôler la permutation du microcontact en agissant à proximité direct du microcontact, afin d'améliorer la transmission de l'information fournie d'une manière économique et simple à mettre en oeuvre.
- Le document
EP 3 640 965 A1 décrit un dispositif d'interaction avec un microcontact selon le préambule de la revendication 1. - A cette fin, la présente divulgation propose un dispositif d'interaction avec un microcontact comprenant:
- un actionneur monté en rotation autour d'un axe entre au moins une première position angulaire et une deuxième position angulaire;
- un microcontact comprenant un corps et un organe mobile monté sur le corps et déplaçable entre une position active et une position de repos ; et
- une lame élastique adaptée pour maintenir l'organe mobile en position active,
- l'organe mobile étant maintenu en position active lorsque l'actionneur est déplacé entre la première position angulaire et une première position intermédiaire, ladite première position intermédiaire étant située entre la première position angulaire et la deuxième position angulaire,
- ledit actionneur étant adapté pour déplacer la lame élastique de façon à ce que l'organe mobile passe dans la position de repos lorsque ledit actionneur est déplacé entre la première position intermédiaire et une deuxième position intermédiaire, ladite deuxième position intermédiaire étant située entre la première position intermédiaire et la deuxième position angulaire.
- Ainsi, avantageusement, la transition de l'organe mobile vers la position de repos peut être différée de la séparation de l'organe mobile et de l'actionneur. Le temps de transmission de l'information fournie par le microcontact peut être adapté.
- Les caractéristiques exposées dans les paragraphes suivants peuvent, optionnellement, être mises en oeuvre. Elles peuvent être mises en oeuvre indépendamment les unes des autres ou en combinaison les unes avec les autres :
- l'actionneur comprend une came adaptée pour appuyer sur l'organe mobile du microcontact et pour déformer la lame élastique ;
- la came comprend une rampe adaptée pour permettre un déplacement progressif de l'organe mobile;
- la lame élastique comprend une portion courbée sur laquelle agit l'actionneur, ladite portion courbée présentant une concavité tournée vers l'axe de l'actionneur ;
- la portion courbée s'étend vers l'organe mobile en présentant une distance croissante par rapport audit axe, de sorte que la lame élastique est progressivement déformée par appui de l'actionneur sur ladite portion courbée entre la première et la deuxième position intermédiaire ;
- la lame élastique comprend une languette, s'étendant dans le prolongement de la portion courbée, adaptée pour maintenir l'organe mobile en position active entre la première position angulaire et la première position intermédiaire;
- la languette a une forme sensiblement en « V » comprenant un sommet, une première branche s'étendant depuis le sommet jusqu'à une première extrémité, une deuxième branche s'étendant depuis le sommet jusqu'à une deuxième extrémité, la deuxième extrémité étant au voisinage du corps du microcontact et la première extrémité étant au voisinage de l'organe mobile du microcontact ;
- la première branche s'étend selon une direction tangentielle à la trajectoire de l'organe mobile, de sorte que l'organe mobile entre au contact de la première branche lors du déplacement de l'organe mobile ;
- la lame élastique comprend une patte de fixation, s'étendant dans le prolongement de la deuxième extrémité de la languette et solidarisée avec le corps du microcontact ;
- l'actionneur est entrainé en rotation lors d'un changement de position de contacts électrique principaux sur une ligne électrique.
- Selon un autre aspect, il est proposé un ensemble de contacts électriques auxiliaires comprenant une pluralité de dispositifs tels que décrits ci-avant, et un arbre solidarisant en rotation les actionneurs de chaque dispositif.
- La caractéristique suivante peut optionnellement être mise en oeuvre : l'arbre est relié par engrenage à un organe de manoeuvre de contacts principaux sur une ligne électrique.
- Selon encore un autre aspect, il est proposé un appareil de connexion électrique comprenant un ensemble tel que décrit ci-avant
- D'autres caractéristiques, détails et avantages apparaîtront à la lecture de la description détaillée ci-après, et à l'analyse des dessins annexés, sur lesquels :
- [
Fig. 1 ] représente schématiquement en perspective un exemple un mécanisme de commande pouvant être mis en oeuvre dans un appareil de connexion électrique. - [
Fig. 2 ] représente schématiquement un détail d'un sous ensemble pouvant être mis en oeuvre dans le mécanisme de commande de lafigure 1 , dans une première position angulaire. - [
Fig. 3 ] représente le détail de lafigure 2 , dans une première position intermédiaire. - [
Fig. 4 ] représente le détail de lafigure 2 , dans une deuxième position intermédiaire. - [
Fig. 5 ] représente le détail de lafigure 2 , dans une deuxième position angulaire. - [
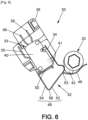
Fig. 6 ] représente le détail de lafigure 2 , dans une troisième position intermédiaire. - [
Fig. 7 ] représente une vue en perspective d'une lame élastique pouvant être mise en oeuvre dans le mécanisme de commande de lafigure 1 . - [
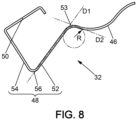
Fig. 8 ] représente une vue de face de la lame élastique de lafigure 7 . - Sur les différentes figures, les mêmes références désignent des éléments identiques ou similaires.
- La
figure 1 illustre de manière schématique un mécanisme de commande 10 pour un appareil de connexion électrique situé sur une ligne électrique de moyenne tension ou de haute tension. Dans ce qui suit, les termes « moyenne tension » et « haute tension » sont utilisés dans leur acceptation habituelle, à savoir que le terme « moyenne tension » désigne une tension qui est supérieure à 1 000 volts en courant alternatif et à 1 500 volts en courant continu mais qui ne dépasse pas 52 000 volts en courant alternatif et 75 000 volts en courant continu, tandis que le terme « haute tension » désigne une tension qui est strictement supérieure à 52 000 volts en courant alternatif et à 75 000 volts en courant continu. - Classiquement, un tel mécanisme de commande 10 comporte un organe de manoeuvre 12 de contacts principaux pour commander l'ouverture ou la fermeture d'une ligne électrique, ainsi qu'un système de transmission 14 du mouvement entre l'organe de manoeuvre 12 des contacts principaux et un ensemble de contacts auxiliaires 11.
- L'ensemble de contacts auxiliaires 11 comprend essentiellement, tel qu'illustré, un arbre 16, une pluralité de microcontacts 18, et un support 25.
- L'arbre 16 est relié au système de transmission 14 des contacts principaux. L'arbre 16 est mobile en rotation autour d'un axe A. L'arbre 16 est destiné à être entrainé en rotation autour de son axe A par le système de transmission 14 lors d'un mouvement de l'organe de manoeuvre 12. L'arbre 16 peut notamment comprendre une roue dentée 19 pour être entrainé par engrenage lors du mouvement de l'organe de manoeuvre 12.
- En outre, l'arbre 16 est solidaire d'une pluralité d'actionneurs 20, disposés régulièrement le long de l'axe A. Chaque actionneur 20 est disposé au regard d'un des microcontacts 18, pour actionner mécaniquement le microcontact 18 lors de la rotation de l'arbre 16 autour de l'axe A.
- Le support 25 permet de monter l'arbre 16 et la pluralité de microcontacts 18 dans le mécanisme de commande 10. Le support 25 présente ici une première platine 22 et une deuxième platine 24, disposée face à la première platine 22. L'arbre 16 est disposé entre les platines 22, 24, selon la direction transversale. Ainsi, l'arbre 16 peut être raccordé aux platines 22, 24, en étant mobile en rotation relatif aux platines 22, 24. Le support 25 présente également une embase 26 s'étendant entre les platines 22, 24. L'embase 26 comprend une pluralité d'alvéoles 28, chaque alvéole 28 définissant un logement 28 pour un des microcontacts 18.
- Par la suite, on décrit plus en détail un dispositif d'interaction 30 entre l'un des actionneurs 20 et l'un des microcontacts 18. Le dispositif 30 comprend le microcontact 18, l'actionneur 20 et une lame élastique 32. La lame élastique 32 s'étend entre l'actionneur 20 et le microcontact 18, pour intervenir dans l'actionnement du microcontact 18.
- Comme plus visible sur la
figure 2 , le microcontact 18 comprend essentiellement un corps 33 et un organe mobile 34 monté sur le corps 33. - Le corps 33 présente ici trois lames 35, 36, 38, faisant saillie d'un boitier 40 du corps 33. Une première lame 35 définit une borne d'alimentation 35 du microcontact 18, pour être reliée à une source de tension ou de courant. Une deuxième lame 36 et une troisième lame 38 définissent respectivement une borne normalement ouverte 36 et une borne normalement fermée 38 du microcontact 18, pour être reliée à un circuit électrique. Le boitier 40 renferme un jeu de contacts internes, pour mettre en contact électrique la borne d'alimentation 35 avec la normalement ouverte 36 ou la borne normalement fermée 38 du microcontact 18. Un déplacement de l'organe mobile 34 provoque la permutation du jeu de contacts internes.
- L'organe mobile 34 prend ici la forme d'une palette 34. La palette 34 interagit avec un poussoir 41, doté d'un ressort de rappel, pour définir une position de repos et une position active de la palette 34. Dans la position de repos, la palette 34 n'exerce pas d'effort sur le poussoir 41. Seul le ressort agit sur le poussoir 41. La borne d'alimentation 35 est en contact électrique avec la borne normalement fermée 38. Dans la position active, la palette 34 est déplacée sous l'effet d'un effort exercé sur la palette 34, pour appuyer sur le poussoir 41, contre l'action du ressort de rappel. La borne d'alimentation 35 est mise en contact électrique avec la borne normalement ouverte 36.
- Par ailleurs, l'actionneur 20 comprend une came 42. Tel qu'illustré, la came 42 prend la forme d'une saillie s'étendant radialement vers l'extérieur par rapport à l'axe A.
- L'actionneur 20 peut adopter une première position angulaire, représentée à la
figure 2 , dans laquelle la came 42 appuie sur l'organe mobile 34 du microcontact 18, pour maintenir l'organe mobile 34 en position active. La première position angulaire peut notamment correspondre à la fermeture de la ligne et à un état fermé de l'appareil de connexion électrique. - Dans une deuxième position angulaire de l'actionneur 20, représentée à la
figure 5 obtenue par rotation autour de l'axe A, la came 42 est séparée de l'organe mobile 34 du microcontact 18. Le microcontact 18 est libéré de l'actionneur 20. La deuxième position angulaire peut correspondre à l'ouverture de la ligne et à un état ouvert de l'appareil de connexion électrique. - La came 42 peut comprendre une rampe 44. La rampe 44 s'étend sur le côté de l'actionneur 20 entrant au contact de l'organe mobile 34 lors de la rotation de l'actionneur 20 de la deuxième position angulaire vers la première position angulaire. Ainsi, lors de la rotation de l'actionneur 20 vers la première position angulaire, l'effort exercé par la came 42 sur l'organe mobile 34 est progressif. La permutation de la position de repos à la position active de l'organe mobile 34 peut être contrôlée par la rampe 44.
- La lame élastique 32 présente, depuis une extrémité au voisinage de l'actionneur 20 à une extrémité au voisinage du microcontact 18, une portion courbée 46, une languette 48 et une patte de fixation 50. La lame élastique 32 intervient dans l'actionnement de l'organe mobile 34 du microcontact 18 lors de la rotation de l'actionneur 20 de la première position angulaire vers la deuxième position angulaire. La permutation de la position active à la position de repos de l'organe mobile 34 peut être contrôlée par la lame élastique 32.
- La portion courbée 46 s'étend autour de l'axe A de l'actionneur 20. La portion courbée 46 définit une concavité tournée vers l'axe A. La portion courbée 46 peut être sollicitée élastiquement par la came 42 de l'actionneur 20. La portion courbée 46 s'étend sur une partie de l'arc de cercle parcouru par la came 42 lors d'une rotation depuis l'une parmi les première et deuxième positions angulaires à l'autre parmi les première et deuxième positions angulaires de l'actionneur 20. La portion courbée 46 est libérée de la came 42 lorsque l'actionneur 20 est dans la première ou la deuxième position angulaire.
- L'extrémité libre de la portion courbée 46, opposée à la languette 48, prend appui sur l'actionneur 20. La portion courbée 46 est fléchie entre l'extrémité libre et la languette 48. En l'espèce, la flexion permet d'éloigner progressivement la portion courbée 46 de l'actionneur 20 par rapport à l'axe A, sur toute l'étendue de la portion courbée 46.
- L'autre extrémité de la portion courbée 46 est reliée à la languette 48 par une articulation 53. L'articulation 53 est disposée au regard de l'organe mobile 34. L'articulation 53 est arrondie. L'articulation 53 définit une convexité orientée vers l'organe mobile 34. L'articulation 53 est destinée à permettre le passage de l'organe mobile 34 lors de son déplacement vers la position active.
- Plus particulièrement, tel qu'illustré à la
figure 8 , des droites D1 et D2 définissent la forme de l'articulation 53. La droite D1 est tangente à l'arc de cercle parcouru par l'organe mobile 34 lors de la permutation entre l'une parmi la position active et la position de repos à l'autre parmi la position de repos et la position active du microcontact 18. La droite D2 est tangente à la portion courbée 46, au voisinage de la languette 48. Les deux extrémités de l'articulation 53 relient les droites D1 et D2 suivant un rayon R. La forme de l'articulation 53 permet ainsi d'éviter que l'organe mobile 34 reste bloqué par la lame élastique 32. - La languette 48 a une forme sensiblement en « V ». Une première branche 52 du « V » s'étend depuis un sommet 56 du « V » jusqu'à l'articulation 53. La première branche 52 s'étend dans le prolongement de l'articulation 53. La première branche 52 est destinée à entrer en contact avec l'organe mobile 34.
- Lors d'un passage de la position active vers la position de repos de l'organe mobile 34, la première branche 52 bloque le passage de l'organe mobile 34. Ici, la première branche 52 bloque l'organe mobile 34 en exerçant un effort sur l'organe mobile 34. L'effort exercé génère un couple de maintien de l'organe mobile 34, supérieur à un couple de libération de l'organe mobile 34 généré par l'action du ressort de rappel sur le poussoir 41. Alternativement, l'organe mobile 34 pourrait être bloqué par frottements ou accrochage de l'organe mobile 34 sur la première branche 52. A l'inverse, lors d'un passage de la position de repos à la position active de l'organe mobile 34, la première branche 52 permet ici le glissement de l'organe mobile 34 le long de la première branche 52.
- Une deuxième branche 54 du « V » s'étend depuis le sommet 56 vers une extrémité au voisinage du microcontact 18. Ainsi, la géométrie de la languette 48 peut permettre la translation de la première branche 52 autour du sommet 56 reliant les deux branches 52, 54. La translation permet d'écarter la première branche 52 de l'organe mobile 34. La forme en « V » facilite la fabrication de la lame élastique 32. Bien entendu, la languette 48 peut prendre toute autre forme pour permettre à la première branche 52 d'être déplacée pour le passage de l'organe mobile 34 entre la position active et la position de repos. Par exemple, l'angle formé par la première et la deuxième branche 52, 54, peut être plus ou moins ouvert. Le sommet 56 du « V » peut également être plus ou moins arrondi.
- Enfin, la patte de fixation 50 s'étend ici le long du corps 33 du microcontact 18. La patte de fixation 50 est solidarisée avec le corps 33 du microcontact 18. La patte de fixation 50 permet d'agencer la lame élastique 32 dans le dispositif 30. On évite ainsi un déplacement de la lame élastique 32 lors de la sollicitation de la lame élastique 32 par la came 42 de l'actionneur 20. L'embase 26 peut être dépourvue de moyens de fixations de la lame élastique 32, facilitant la fabrication de l'embase 26 et l'assemblage du dispositif 30.
- L'actionneur 20 peut adopter une première et une deuxième position intermédiaire, illustrées respectivement par les
figures 3 et4 , en se déplaçant depuis la première position angulaire vers la deuxième position angulaire. Les première et deuxième positions intermédiaires correspondent à une position de l'actionneur 20 en cours d'ouverture de l'appareil de connexion électrique. La deuxième position intermédiaire est postérieure à la première position intermédiaire lors du mouvement de l'actionneur 20, et est associée à la libération du microcontact 18 de la lame élastique 32. - Dans la première position intermédiaire, illustrée à la
figure 3 , la came 42 de l'actionneur 20 entre au contact avec la portion courbée 46. La lame élastique 32 n'est pas sollicitée par la came 42 tant que l'actionneur 20 n'est pas dans la première position intermédiaire. Dans la deuxième position intermédiaire, illustrée à lafigure 4 , l'extrémité de la came 42 est au voisinage de l'extrémité libre de la portion courbée 46. La came 42 appuie sur la portion courbée 46. - L'actionneur 20 peut également adopter une troisième position intermédiaire, illustrée par la
figure 6 , en se déplaçant depuis la deuxième position angulaire vers la première position angulaire. La troisième position intermédiaire correspond à une position de l'actionneur 20 en cours de fermeture de l'appareil de connexion électrique. - Par la suite, on décrit le fonctionnement du dispositif 30 décrit ci-avant.
- Initialement, l'actionneur 20 est dans la première position angulaire, illustrée à la
figure 2 . La came 42 de l'actionneur 20 agit sur l'organe mobile 34 du microcontact 18 pour maintenir l'organe mobile 34 dans la position active. Alors, la borne d'alimentation 35 du microcontact 18 est reliée à la borne normalement ouverte 36 du microcontact 18. Le courant traversant le microcontact 18 peut par exemple informer que la ligne est dans la position fermée. - Si la ligne passe en position ouverte, l'actionneur 20 est entrainé vers la deuxième position angulaire, illustrée à la
figure 5 . La came 42 de l'actionneur 20 libère l'organe mobile 34. La lame élastique 32 maintien en position active l'organe mobile 34 du microcontact 18. L'organe mobile 34 est maintenu en position active sous l'effet de la languette 48, notamment de la première branche 52 de la languette 48. La première branche 52 bloque le passage de l'organe mobile 34. - Lorsque l'actionneur 20 atteint la première position intermédiaire, illustrée à la
figure 3 , la came 42 de l'actionneur 20 entre au contact de la portion courbée 46 de la lame élastique 32, puis exerce un effort croissant sur la portion courbée 46. L'effort exercé sur la portion courbée 46 par la came 42 entraine la translation de la première branche 52 de la lame élastique 32. - Lorsque l'actionneur 20 atteint la deuxième position intermédiaire, illustrée en
figure 4 , l'effort exercé par la came 42 de l'actionneur 20 sur la portion courbée 46 est maximal. La translation de la première branche 52 de la languette 48 est suffisante pour séparer la première branche 52 de l'organe mobile 34. L'organe mobile 34 est libéré de l'action de la lame élastique 32. L'organe mobile peut alors atteindre la position de repos. - Lors de la poursuite de la rotation de l'actionneur 20 vers la deuxième position angulaire, l'effort exercé par la came 42 de l'actionneur 20 sur la portion courbée 46 est décroissant. La rampe 44 de la came 42 ramène progressivement la portion courbée 46 de la lame élastique 32 vers la position initiale de la
figure 2 . - Lorsque l'actionneur 20 est dans la deuxième position angulaire, illustrée à la
figure 5 , la came 42 de l'actionneur 20 est séparée de l'organe mobile 34 et de la lame élastique 32. La lame élastique 32 est à la position initiale de lafigure 2 . L'organe mobile 34 du microcontact 18 est dans la position de repos. Alors, la borne d'alimentation 35 du microcontact 18 est reliée à la borne normalement fermée 38 du microcontact 18. Le courant traversant le microcontact 18 peut par exemple informer que la ligne est dans une position ouverte. - Si la ligne est ramenée à la position fermée, l'actionneur 20 est entrainé vers la première position angulaire de la
figure 2 . La came 42 de l'actionneur 20 entre en contact avec la portion courbée 46 de la lame élastique 32, puis exerce un effort sur la portion courbée 46. - Lorsque l'actionneur 20 rejoint la troisième position intermédiaire illustrée à la
figure 6 , la rampe 44 entre au contact de l'organe mobile 34, pour progressivement pousser le contact mobile 34 vers la position active. Le déplacement de l'organe mobile 34 rapproche l'organe mobile 34 de l'articulation 53 de la lame élastique 32. L'articulation 53 permet le passage de l'organe mobile 34. L'organe mobile 34 peut alors venir au contact de la première branche 52, puis glisser le long de la première branche 52. - La poursuite de la rotation de l'actionneur 20 entraine la séparation de la came 42 et de la portion courbée 46. Seul l'organe mobile 34 agit sur la lame élastique 32. L'organe mobile 34, poussé par la rampe 44 de l'actionneur 20, exerce un effort sur la lame élastique 32. L'effort exercé par l'organe mobile 34 entraine la translation de la première branche 52. L'organe mobile rejoint la position active, illustrée à la
figure 2 , sans être bloqué par la lame élastique 32. Ainsi, la lame élastique 32 n'entrave pas à la permutation de l'organe mobile de la position de repos vers la position active. - Selon une autre variante de l'invention, la deuxième position angulaire de l'actionneur 20 peut correspondre à la mise à la terre de la ligne. Le dispositif 30 peut alors informer de la mise à la terre de la ligne.
Claims (13)
- Dispositif (30) d'interaction avec un microcontact (18) comprenant:- un actionneur (20) monté en rotation autour d'un axe (A) entre au moins une première position angulaire et une deuxième position angulaire ;- un microcontact (18) comprenant un corps (33) et un organe mobile (34) monté sur le corps (33) et déplaçable entre une position active et une position de repos ; l'organe mobile (34) étant maintenu en position active lorsque l'actionneur (20) est déplacé entre la première position angulaire et une première position intermédiaire, ladite première position intermédiaire étant située entre la première position angulaire et la deuxième position angulaire,caractérisé en ce que le dispositif d'interaction comprend une lame élastique (32) adaptée pour maintenir l'organe mobile (34) en position active,ledit actionneur (20) étant adapté pour déplacer la lame élastique (32) de façon à ce que l'organe mobile (34) passe dans la position de repos lorsque ledit actionneur (20) est déplacé entre la première position intermédiaire et une deuxième position intermédiaire, ladite deuxième position intermédiaire étant située entre la première position intermédiaire et la deuxième position angulaire.
- Dispositif selon la revendication 1, dans lequel l'actionneur (20) comprend une came (42) adaptée pour appuyer sur l'organe mobile (34) du microcontact (18) et pour déformer la lame élastique (32).
- Dispositif selon la revendication 2, dans lequel la came (42) comprend une rampe (44) adaptée pour permettre un déplacement progressif de l'organe mobile (34).
- Dispositif selon l'une des revendications 1 à 3, dans lequel la lame élastique (32) comprend une portion courbée (46) sur laquelle agit l'actionneur (20), ladite portion courbée (46) présentant une concavité tournée vers l'axe (A) de l'actionneur (20).
- Dispositif selon la revendication 4, dans lequel la portion courbée (46) s'étend vers l'organe mobile (34) en présentant une distance croissante par rapport audit axe (A), de sorte que la lame élastique (32) est progressivement déformée par appui de l'actionneur (20) sur ladite portion courbée (46) entre la première et la deuxième position intermédiaire.
- Dispositif selon l'une des revendications 4 ou 5, dans lequel la lame élastique (32) comprend une languette (48), s'étendant dans le prolongement de la portion courbée (46), adaptée pour maintenir l'organe mobile (34) en position active entre la première position angulaire et la première position intermédiaire.
- Dispositif selon la revendication 6, dans lequel la languette (48) a une forme sensiblement en « V » comprenant un sommet (56), une première branche (52) s'étendant depuis le sommet (56) jusqu'à une première extrémité, une deuxième branche (54) s'étendant depuis le sommet (56) jusqu'à une deuxième extrémité, la deuxième extrémité étant au voisinage du corps (33) du microcontact (18) et la première extrémité étant au voisinage de l'organe mobile (34) du microcontact (18).
- Dispositif selon la revendication 7, dans lequel la première branche (52) s'étend selon une direction tangentielle à la trajectoire de l'organe mobile (34), de sorte que l'organe mobile (34) entre au contact de la première branche (52) lors du déplacement de l'organe mobile (34).
- Dispositif selon l'une des revendications 6 à 8, dans lequel la lame élastique (32) comprend une patte de fixation (50), s'étendant dans le prolongement de la deuxième extrémité de la languette (48) et solidarisée avec le corps (33) du microcontact (18).
- Dispositif selon l'une quelconque des revendications précédentes, dans lequel l'actionneur (20) est entrainé en rotation lors d'un changement de position de contacts électrique principaux sur une ligne électrique.
- Ensemble (10) de contacts électriques auxiliaires comprenant une pluralité de dispositifs (30) selon l'une quelconque des revendications précédentes, et un arbre (16) solidarisant en rotation les actionneurs (20) de chaque dispositif (30).
- Ensemble (10) de contacts électriques auxiliaires selon la revendication 11, dans lequel l'arbre (16) est relié par engrenage à un organe de manoeuvre (12) de contacts principaux sur une ligne électrique.
- Appareil de connexion électrique comprenant un ensemble (10) selon l'une des revendications 11 ou 12.
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| FR2009453A FR3114435A1 (fr) | 2020-09-18 | 2020-09-18 | Dispositif pour le contrôle d’un microcontact dans un appareil de connexion électrique |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP3971934A1 EP3971934A1 (fr) | 2022-03-23 |
| EP3971934B1 true EP3971934B1 (fr) | 2024-10-30 |
Family
ID=73643054
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP21181668.1A Active EP3971934B1 (fr) | 2020-09-18 | 2021-06-25 | Dispositif pour le contrôle d'un microcontact dans un appareil de connexion électrique |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP3971934B1 (fr) |
| CN (1) | CN114203463A (fr) |
| FR (1) | FR3114435A1 (fr) |
Family Cites Families (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4110327C1 (en) * | 1991-03-28 | 1992-07-30 | S. Siedle & Soehne Telefon- Und Telegrafenwerke Stiftung & Co, 7743 Furtwangen, De | Actuator for pushbutton microswitch - has lever pivoted by rod to press operating button of cradle switch of telephone subscriber's appts. when handset is replaced |
| DE19860042A1 (de) * | 1998-12-23 | 2000-07-06 | Aeg Niederspannungstech Gmbh | Betätigungselement zur Herstellung einer Schaltverbindung zwischen einem Hauptschalter und einem Hilfsschalter |
| KR100876412B1 (ko) * | 2007-07-12 | 2008-12-31 | 엘에스산전 주식회사 | 차단기의 지연시간 출력장치 |
| CN101436493B (zh) * | 2008-12-05 | 2011-01-12 | 常熟开关制造有限公司(原常熟开关厂) | 断路器辅助开关 |
| CN102386002B (zh) * | 2010-08-31 | 2014-11-26 | 西门子公司 | 辅助开关及其切换装置 |
| CN202816820U (zh) * | 2012-08-17 | 2013-03-20 | 上海电科电器科技有限公司 | 断路器的辅助开关 |
| EP3166121B1 (fr) * | 2015-11-03 | 2019-03-27 | C&K Components SAS | Interrupteur à bouton-poussoir électrique |
| FR3061987B1 (fr) * | 2017-01-16 | 2019-04-19 | Schneider Electric Industries Sas | Integration de contacts electriques a un appareil de connexion electrique |
| FR3087273B1 (fr) * | 2018-10-15 | 2020-11-06 | Schneider Electric Ind Sas | Dispositif de mesure et appareil de commutation electrique |
| CN209118946U (zh) * | 2018-12-04 | 2019-07-16 | 四川凌峰航空液压机械有限公司 | 微动开关缓冲促动机构 |
| CN210378863U (zh) * | 2019-10-28 | 2020-04-21 | 保定天威恒通电气有限公司 | 一种便于扩展安装的隔离开关辅助触点装置 |
-
2020
- 2020-09-18 FR FR2009453A patent/FR3114435A1/fr not_active Ceased
-
2021
- 2021-06-25 EP EP21181668.1A patent/EP3971934B1/fr active Active
- 2021-08-17 CN CN202110941108.0A patent/CN114203463A/zh active Pending
Also Published As
| Publication number | Publication date |
|---|---|
| CN114203463A (zh) | 2022-03-18 |
| EP3971934A1 (fr) | 2022-03-23 |
| FR3114435A1 (fr) | 2022-03-25 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP0570647B1 (fr) | Mécanisme de serrure pour disjoncteur et disjoncteurs l'incorporant | |
| EP2061059B1 (fr) | Dispositif de commande d'un appareil électrique de coupure, et appareil électrique de coupure le comportant | |
| EP0161120B1 (fr) | Combiné pour coupure en charge et le sectionnement visible d'un circuit électrique | |
| FR2789511A1 (fr) | Installation comportant un appareillage electrique de coupure et un interverrouillage a cable | |
| EP2061058B1 (fr) | Dispositif de commande d'un appareil de coupure électrique et appareil de coupure électrique le comportant | |
| EP3487006B1 (fr) | Système électrique comprenant un appareil électrique et un module de connexion interchangeable | |
| FR2597658A1 (fr) | Commutateur miniature a rupture brusque | |
| FR3056330A1 (fr) | Dispositif de coupure comportant un organe de rearmement | |
| EP2365510B1 (fr) | Dispositif de coupure | |
| EP0564379B1 (fr) | Mécanisme de commande à palonnier pour disjoncteur électrique à phase et neutre | |
| EP2717284B1 (fr) | Dispositif de commande d'un appareil de protection électrique et appareil de protection électrique le comportant | |
| EP3971934A1 (fr) | Dispositif pour le contrôle d'un microcontact dans un appareil de connexion électrique | |
| EP1734552B1 (fr) | Dispositif d'actionnement d'un appareil électrique interrupteur à moyens de blocage en rotation | |
| EP0564380B1 (fr) | Mécanisme de commande à tiroir pour disjoncteur électrique à phase et neutre | |
| EP0209433B1 (fr) | Pièce de support de contacts mobiles, notamment pour appareil interrupteur de protection | |
| EP0891627B1 (fr) | Dispositif modulaire de commutation electrique | |
| EP2061060B1 (fr) | Appareil électrique de coupure tel un disjoncteur ou un interrupteur | |
| EP3605581B1 (fr) | Appareil de commutation électrique à contacts séparables | |
| FR2735609A1 (fr) | Mecanisme d'interrupteur | |
| EP1296342B1 (fr) | Sectionneur à fusible comprenant un porte-fusible et un élément de commande pour un circuit de sécurité | |
| EP3792949B1 (fr) | Appareil de commutation électrique à contacts séparables | |
| EP0517639B1 (fr) | Connecteur à faible encombrement pour borne de batterie automobile | |
| EP1632970B1 (fr) | Déclencheur électromagnétique et appareil de coupure électronique le comportant | |
| FR2626712A1 (fr) | Interrupteur electrique a coupure automatique, en particulier interrupteur differentiel | |
| FR2530072A1 (fr) | Dispositif commutateur, notamment disjoncteur du type a enclenchement par enfoncement puis relachement d'un bouton-poussoir et a declenchement par la deformation d'une lame bimetallique |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20220913 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20240321 |
|
| GRAJ | Information related to disapproval of communication of intention to grant by the applicant or resumption of examination proceedings by the epo deleted |
Free format text: ORIGINAL CODE: EPIDOSDIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTC | Intention to grant announced (deleted) | ||
| INTG | Intention to grant announced |
Effective date: 20240619 |
|
| GRAJ | Information related to disapproval of communication of intention to grant by the applicant or resumption of examination proceedings by the epo deleted |
Free format text: ORIGINAL CODE: EPIDOSDIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| INTC | Intention to grant announced (deleted) | ||
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| INTG | Intention to grant announced |
Effective date: 20240919 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602021020883 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: FRENCH |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250228 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250228 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MK05 Ref document number: 1737793 Country of ref document: AT Kind code of ref document: T Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250130 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250131 Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250130 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250626 Year of fee payment: 5 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20250617 Year of fee payment: 5 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20250624 Year of fee payment: 5 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602021020883 Country of ref document: DE |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| 26N | No opposition filed |
Effective date: 20250731 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: H13 Free format text: ST27 STATUS EVENT CODE: U-0-0-H10-H13 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260127 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241030 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250625 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20250630 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250625 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250630 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250630 |