EP3420794B1 - System zur ertragsmessung und verfahren zum betreiben eines systems zur ertragsmessung - Google Patents
System zur ertragsmessung und verfahren zum betreiben eines systems zur ertragsmessung Download PDFInfo
- Publication number
- EP3420794B1 EP3420794B1 EP18163855.2A EP18163855A EP3420794B1 EP 3420794 B1 EP3420794 B1 EP 3420794B1 EP 18163855 A EP18163855 A EP 18163855A EP 3420794 B1 EP3420794 B1 EP 3420794B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- conveying device
- electric motor
- bulk material
- conveying
- container
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01D—HARVESTING; MOWING
- A01D41/00—Combines, i.e. harvesters or mowers combined with threshing devices
- A01D41/12—Details of combines
- A01D41/127—Control or measuring arrangements specially adapted for combines
- A01D41/1271—Control or measuring arrangements specially adapted for combines for measuring crop flow
- A01D41/1272—Control or measuring arrangements specially adapted for combines for measuring crop flow for measuring grain flow
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01F—MEASURING VOLUME, VOLUME FLOW, MASS FLOW OR LIQUID LEVEL; METERING BY VOLUME
- G01F25/00—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume
- G01F25/10—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume of flowmeters
- G01F25/14—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume of flowmeters using a weighing apparatus
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01F—MEASURING VOLUME, VOLUME FLOW, MASS FLOW OR LIQUID LEVEL; METERING BY VOLUME
- G01F25/00—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume
- G01F25/10—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume of flowmeters
- G01F25/17—Testing or calibration of apparatus for measuring volume, volume flow or liquid level or for metering by volume of flowmeters using calibrated reservoirs
Definitions
- the present invention relates to a system for yield measurement according to the preamble of claim 1. Furthermore, the invention relates to a method for operating a system for yield measurement according to claim 7 and an agricultural work vehicle according to claim 14.
- Yield measurement systems are used in particular in scenic work vehicles to determine the amount of bulk material harvested per unit area during a harvesting process.
- An agricultural work vehicle can be, for example, a self-propelled harvesting machine with a container for receiving bulk material or a transport vehicle pulled by a tractor with a container, such as a transfer vehicle.
- the yield measurement is used, among other things, by a landscaping company for internal business evaluation or by a contractor commissioned with the harvesting process for billing purposes.
- Such a system for yield measurement comprises a container for receiving, in particular, agricultural bulk material, a conveying device comprising at least one conveying component for feeding bulk material into the container, at least one first sensor device for determining the volume or weight of the bulk material conveyed into the container by the conveying device , as well as a control device which is set up to evaluate the signals of the at least one first sensor device.
- a system for yield measurement and a method for operating a system for yield measurement are from EP 2 960 634 A1 known.
- the EP 2 960 634 A1 describes a container for receiving bulk material to which bulk material is fed by a conveyor device.
- the bulk material emerging from the conveying device is recorded by a mass flow rate sensor.
- the mass flow rate sensor is designed as a load cell.
- accumulation sensors are arranged below the container. The accumulation sensors periodically monitor the accumulation of bulk material in the container during the filling process, which determines the extent to which the weight of the cone of material changes.
- the signal from the accumulation sensors is used by a control device in order to determine a calibration factor which is applicable to the mass flow rate sensor.
- the WO2012088405 A1 describes a device and a method with the features of the preamble of claims 1 and 7. Based on this prior art, the object of the invention is to provide a system for yield measurement and a method for operating a system for yield measurement, which is simpler Construction excels.
- a system for yield measurement comprising a container for receiving bulk material, a conveyor device comprising at least one conveyor component for feeding bulk material into the container, at least one first sensor device for determining the Volume or weight of the bulk material conveyed into the container by the conveying device, as well as a control device which is set up to evaluate the signals of the at least one first sensor.
- the first sensor device used to measure the yield can be based on the functional principle of volume flow measurement, which can in particular take place without contact, or a force / pulse measurement. In the latter case, the mass flow is determined from this.
- At least one delivery component can be driven by an electric motor and that the delivery device is assigned at least one additional sensor device for measuring at least one physical variable of the electric motor, by means of which a torque recorded by the delivery component is transmitted through the Control device is determinable.
- the torque absorbed by the conveying component or the torque curve correlate with the mass of the bulk material conveyed by the conveying component.
- the determination of the torque absorbed by the delivery component can be used to measure the yield by means of a suitable signal evaluation.
- the measured values for the mass conveyed by the conveying component by means of the torque determined by the control device are used to calibrate the first sensor.
- the arrangement of accumulation sensors assigned to the container for receiving bulk material can be dispensed with, and on the other hand, the use of an electric motor to drive the at least one conveying component of the conveying device offers advantages in its operation due to the good controllability of the electric motor.
- the use of the electric motor to drive the at least one conveying component of the conveying device results in a synergy effect, namely the simplification of the calibration of the yield measurement.
- the conveying component driven by the electric motor is the component of the conveying device from which the bulk material emerges directly into the container or is transferred to the container.
- An electric motor drive of one or more components of the conveying device is of course conceivable in order to be able to determine in a corresponding manner the torque absorbed by at least one of these electric motor driven components.
- the control device is set up to measure the at least one physical variable of the electric motor as a function of a detected fill level of the bulk material in the container.
- the measurement of the at least one physical variable can take place within a filling level interval which corresponds to a defined volume of the bulk material received by the container.
- at least one fill level sensor is assigned in the container, which signals the respective reaching of a percentage of the maximum fill level to an operator.
- the at least one level sensor can be designed, for example, as an optical sensor or as a mechanical sensor. At least two fill level sensors are preferably used. Thus, reaching a first, lower filling level, which is detected by a first filling level sensor, can mark the beginning of the measurement of the at least one physical variable.
- the end of the measurement of the at least one physical variable is marked when the second, higher fill level is reached with a time delay, which is detected by a second fill level sensor.
- a defined volume is conveyed into the container by the conveying device. That within the The volume conveyed within the filling level interval and the torque curve determined within the filling level interval by measuring the at least one physical variable can be used as an automatic adjustment or calibration value for the yield measurement for the at least one first sensor device.
- control device is set up to carry out an initial measurement of the at least one physical variable of the electric motor in the load-free state of the conveying device.
- the measurement of the at least one physical variable determines the torque that the conveying component driven by the electric motor absorbs when the latter does not convey bulk material. This allows the accuracy of the calibration process to be increased.
- the initial measurement can be used to determine the no-load torque caused by friction between the conveyor component and its mounting.
- the control device can be set up to automatically carry out the initial measurement within time windows when the conveying device is in an operating state within which the conveying of bulk material is not carried out.
- exemplary operating states can include unloading when the combine harvester is at a standstill or when driving on headlands.
- Such operating situations can be determined by the control device on the basis of internal and external operating parameters of the agricultural work vehicle.
- the process of the initial measurement can also be started manually by an operator.
- control device can be set up to store characteristic curves or characteristic curve fields for torque curves of the at least one conveying component of the conveying device driven by the electric motor.
- the control device comprises at least one processor unit, at least one memory unit and input-output interfaces.
- the characteristic curves or characteristic curve fields that can be stored in the at least one storage unit can be crop-specific, which can be of importance in particular for the respective weight or the respective density of the bulk material, and / or take into account different moisture content of the bulk material.
- the torque absorbed by the conveyor component is a measure of the weight of the bulk material being transported. However, regardless of whether the conveying component is transporting more bulk goods, bulk goods with a higher density or very moist bulk goods.
- the characteristic curves or characteristic curves map the relationship between the torque absorbed by the conveyor component of the conveyor device, which is driven by an electric motor, and the mass of the bulk material. Furthermore, the characteristic curves or characteristic curve fields that can be stored represent the relationship between the respective bulk material type or fruit type of the harvested material and its moisture values. In addition, characteristic curves or characteristic curve fields can also be stored which contain torque curves that can arise due to wear of the at least one electric motor-driven conveying component of the conveying device. As a result, in the course of determining the torque absorbed by the delivery component, system defects or limitations of the delivery component driven by an electric motor could be detected. This can take place in particular during an initial measurement.
- the at least one further sensor device can be set up to measure current as at least one physical variable.
- the torque can be determined indirectly by measuring the current at constant voltage or by measuring the current and voltage at variable voltage, since the current is proportional to the torque.
- the measured values for the current and the voltage can also be used to calculate an output from the electric motor electrical power can be used by the control device.
- the drive speed of the electric motor is measured to regulate it, for example with a resolver or a Hall sensor.
- the control device can preferably be set up to control the electric motor by means of a frequency converter as a function of at least one operating parameter of the conveyor device.
- An operating parameter can be, for example, the throughput of the conveying device.
- a gentle start-up and braking of the conveying component can also be represented.
- the throughput-dependent control of the drive speed of the conveying component has the advantage that wear and tear and the noise level of the conveying device can be reduced.
- Further operating parameters of the conveying device can be the moisture or a risk of breakage of the bulk material. If the conveying speed of the conveying component is too high, both have a disadvantageous effect on the quality of the bulk material.
- Another advantage results from the fact that the frequency converter already provides corresponding current and / or voltage signals that can be evaluated by the control device. There is no need to assign additional sensors to the container to determine these physical variables, as is the case in the prior art mentioned at the beginning.
- the system can comprise a moisture sensor for determining the moisture of the bulk material conveyed by the conveying device.
- a moisture sensor for determining the moisture of the bulk material conveyed by the conveying device.
- Such a sensor is used to detect the moisture in the bulk material in order to be able to determine the actual weight, that is to say the dry matter, of the bulk material received by the container.
- the determination of the torque curve during a filling level interval can also be used to calibrate the moisture sensor.
- the volume conveyed within the level interval as well as that within the level interval Certain torque curves can be used as an automatic adjustment or calibration value for the moisture measurement by the moisture sensor.
- the object is achieved by a method for operating a system for measuring yield according to the independent claim 7.
- the independent claim 7 proposes a method for operating a yield measurement system, wherein bulk material is fed to a container from a conveyor device comprising at least one conveyor component, the weight or volume of which is determined by a control device by evaluating signals from at least one first sensor device.
- the method is characterized in that at least one conveying component of the conveying device is driven by an electric motor, with a torque recorded by the conveying device being determined by measuring at least one physical variable of the electric motor by means of at least one further sensor device to calibrate the yield measurement.
- the bulk material mass conveyed by the conveying component or the conveying device correlates with the torque absorbed by the conveying component.
- the measurements of at least one of the physical variables can be carried out within at least one fill level interval.
- a level monitoring of the bulk goods receiving container is generally implemented by at least one level sensor assigned to the container.
- the at least one level sensor assigned to the container is connected to the control device for signaling purposes in order to transmit level data to the latter for evaluation. If a first threshold value is reached or passed while the container is being filled, the measurement of at least a physical variable for determining the torque can be automatically initiated by the control device. When a second threshold value of the fill level is reached, the measurement is automatically terminated by the control device.
- the bulk material volume taken up by the container within the filling level interval is used together with the bulk material mass determined by the determination of the torque as an automatic adjustment value for the yield measurement.
- An initial measurement of the at least one physical variable of the electric motor can preferably be carried out in a load-free state of the conveying device.
- the required torque of the at least one electric motor-driven conveying component can be determined, which is due to friction between the conveying component and its mounting. This allows the accuracy of the method to be increased.
- Suitable operating states of the conveying device can be used to carry out the initial measurement, during which conveyance of bulk material by the conveying device is not to be expected. Such operating states can be determined by an operator who manually triggers an initial measurement. Alternatively, such operating states can be determined by the control device on the basis of provided internal and external operating parameters, so that the control device can initiate the initial measurement in an automated manner.
- the initial measurement of the at least one physical variable of the electric motor can be carried out repeatedly while the conveyor device is in operation.
- parameter changes which can have an influence on the operation of the conveyor device, can be taken into account.
- the occurrence of an operating state suitable for repeated implementation of the initial measurement can be detected by the control device.
- At least the current can be measured and evaluated.
- the measurement of the current at constant voltage or of the current and the voltage at variable voltage has the advantage that it can be implemented with less technical effort.
- a frequency converter provided for controlling the electric motor provides corresponding signals for the current and the voltage as physical quantities.
- a torque sensor, which is assigned to the at least one delivery component, can thus be omitted.
- the torque absorbed by the delivery component is determined indirectly by the current measurement, since it is always proportional to the current.
- the moisture of the bulk material conveyed by the conveying device is determined.
- a calibration of a moisture sensor provided for this purpose can be carried out in a corresponding manner in the calibration of the yield measurement. Knowing the amount of bulk material conveyed within a filling level interval and the bulk material volume, the moisture can be inferred if the density of the bulk material is known.
- control device can be used to create a characteristic curve or a characteristic curve field for a torque curve of the delivery component.
- the type of bulk material of the control device can be specified and the measurement curves of the moisture measurement, the current measurement and the weight or volume measurement can be recorded and evaluated by the control device.
- the control device can be set up accordingly for this purpose.
- an agricultural work vehicle is proposed, characterized by a system for yield measurement according to one of Claims 1 to 7, the agricultural work vehicle being set up to carry out a method according to one of Claims 8 to 14.
- an electric motor Driven conveying component comes into consideration, for example, in an agricultural work vehicle designed as a combine harvester, the grain tank discharge screw.
- the electric motor drive of the so-called grain elevator is also conceivable.
- FIG. 1 is a schematic view of an agricultural work vehicle designed as a combine harvester 30 with a container designed as a grain tank 39 for receiving bulk material-shaped crops.
- combine harvester 30 has an attachment 32 designed as a cutting mechanism.
- the crop 31 harvested by the front attachment 32 is fed to a threshing device 33 in which the crop 31 is separated.
- the crop components separated in the threshing device 33 essentially grain in bulk form and non-grain components, are fed to a cleaning device 35 in order to separate the grain in bulk form from the non-grain components.
- the grain is fed to a transverse screw conveyor 37, which the grain to a grain elevator 38 promotes.
- the grain elevator 38 conveys the grain into the grain tank 39 by means of a grain tank discharge screw (not shown). Furthermore, the combine harvester 30 comprises a separating device 34, a chopping and distributing device 36 and a driver's cab 40. The grain bunkered in the grain tank 39 is transferred to a loading wagon through a grain tank outlet pipe 41 Overloaded for removal.
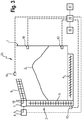
- FIG. 2 A schematic view of a system 20 for yield measurement is shown, comprising a container 1 with a conveying device 3.
- the container 1 can be the grain tank 39 and the conveying device 3 can be the transverse screw conveyor 37, the grain elevator 38 and the grain tank discharge screw (not shown) Combine 30 act.
- the container 1 is used to hold bulk material 2, in particular grain.
- the conveyor device 3 comprises at least one conveyor component.
- the conveyor device 3 comprises several conveyor components, a cross conveyor component 4, a vertical conveyor component 5 and a discharge component 6. Bulk material is conveyed from the cross conveyor component 4 to the vertical conveyor component 5, which feeds the bulk material in a substantially vertical direction to the discharge component 6, which the Conveying bulk material into the container 1.
- the discharge component 6 is designed as a screw conveyor in the exemplary embodiment shown. At least the discharge component 6 is driven by an electric motor 7.
- the electric motor 7 can be controlled by means of a frequency converter 8.
- the frequency converter 8 has at least one sensor 9 for measuring the current and / or the voltage.
- the electric motor 7 is equipped with a speed sensor 10 designed as a Hall sensor or resolver.
- the good controllability of the discharge component 6 driven by an electric motor offers various advantages, such as a gentle start and stop of the discharge component 6 or a throughput-dependent speed control of the discharge component 6 in order to reduce component wear and the noise level.
- the risk of damage to the bulk material such as the Reduce the risk of broken grains by adjusting the speed accordingly.
- the system 20 for yield measurement has a first sensor device 11 assigned to the conveying device 3, which serves to determine the weight or the volume of the bulk material 2 conveyed by the conveying device 3.
- the first sensor device 11 can operate without contact in order to determine the bulk material volume conveyed by the vertical conveyor component 5.
- the first sensor device 11 can be configured, for example, in the form of a light barrier, as is shown in FIG EP 0 931 445 A1 is known.
- the sensor device 11 can also be designed as a load cell in order to determine the weight of the conveyed bulk material 2.
- a moisture sensor 12 is assigned to the conveying device 3, with which the moisture of the bulk material 2 is measured continuously.
- At least one level sensor is arranged in which in Figure 2
- the illustrated embodiment, two level sensors 13, 14 are provided, which are designed as mechanical buttons.
- the at least one fill level sensor can also be designed as an optical sensor.
- One fill level sensor 13 is arranged near the bottom on a side wall of the container 1, while the other fill level sensor 14 is arranged at a distance from this in the upper region of the side wall of the container 1.
- the positioning of the level sensors 13 and 14 is selected in such a way that a defined volume is established between them.
- the position of the fill level sensor 13 can correspond to a fill level of the container 1 of, for example, 30%, while the position of the fill level sensor 14 corresponds to a fill level of the container 1 of, for example, 70%. Positioning of the fill level sensors that deviates from this is conceivable.
- the system 20 for yield measurement comprises a control device 15, which is connected to the sensor 9 of the frequency converter 8, the Speed sensor 10, the first sensor device 11, the moisture sensor 12 and the level sensors 13 and 14 is connected for signaling purposes.
- the reference number 17 denotes an input / output device which is also connected to the control device 15 by the bus system 16. The input / output device 17 enables an operator to interact with the control device 15.
- FIG 3 is a schematic view of the container with the conveying device 3 according to a further embodiment.
- a load cell for force / pulse measurement is provided as a first sensor device 18 in order to determine the weight of the bulk material 2 conveyed by the conveying device 3.
- This first sensor device 18 is also connected to the control device 15 for signaling purposes by the bus system 16. Otherwise, the structure of the system 20 for yield measurement does not differ from that in Figure 2 shown.
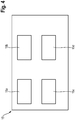
- control device 15 of the system 20 for yield measurement according to the embodiments described above is shown schematically.
- the control device 15 comprises at least one processor unit 15a, at least one memory unit 15b, and one or more input-output interfaces 15c, 15d.
- Characteristic curves or characteristic curve fields for torque curves at least of the discharge component 6 driven by the electric motor 7 can be stored in the at least one storage unit 15b.
- the control device 15 receives the measured values from the first sensor device 11 and 18 as well as the moisture sensor 12 and the fill level sensors 13 and 14.
- the process sequence is described below using the in Figure 2 illustrated embodiment explained.
- the torque absorbed by the delivery component 6 correlates with that delivered by the delivery component 6 Mass of the bulk material 2.
- the torque is proportional to the current, which is continuously measured by the sensor 9 of the frequency converter 8.
- a mass of the bulk material 2 can be assigned to a particular torque. Direct measurement of the torque by means of a torque sensor is also conceivable.
- the determination of the torque or the torque curve takes place within a filling level interval.
- the beginning and end of the filling level interval are detected by the filling level sensors 13 and 14. If the filling level sensor 13 is activated by the filling of the container 1, the corresponding signal of the filling level sensor 13 is processed by the control device 15 in order to automatically start the measuring process for determining the torque. If the level in the container 1 reaches a level which activates the level sensor 14, the corresponding signal from the level sensor 13 is processed by the control device 15 in order to automatically end the measuring process.
- the bulk material mass fed to the container 1 by the discharge component 6 within the filling level interval can be determined by means of the characteristic curves or characteristic fields of torque curves stored in the memory unit 15b.
- the control device 15 assigns a mass to a torque.
- the defined volume known between the level sensors 13 and 14 is automatically used together with the mass determined from the torque as an adjustment value for the yield and moisture measurement. With this adjustment value, it is possible to continuously compensate for density fluctuations that occur during the supply of bulk material 2 into the container 1 can. For example, when harvesting an agricultural product within a field to be harvested, fluctuations in yield can occur, among other things, which can be attributed to an uneven stand density.
- At least one initial measurement takes place, during which the torque absorbed by the discharge component 6 in the no-load state, ie. H. without conveying bulk material 2, is determined.
- Such an initial measurement can be carried out automatically within certain time windows in which there is no material flow in the conveying device 3.
- the control device 15 the control device 15.
- the discharge component 6 of the conveying device 3 which is designed as a grain tank discharge screw, can no longer throw the bulk grain freely into the grain tank 39 from a fill level above the fill level sensor 14, but can throw it upwards postpones. This leads to the grain being compressed more strongly in the grain tank discharge screw, so that under certain circumstances it is no longer possible to compensate for the fluctuations in density with sufficient accuracy. When an upper level limit is passed, the density fluctuation is compensated using the last determined adjustment value.
- the method for operating the system 20 for yield measurement is particularly advantageous since the method can be carried out repeatedly without great effort. This allows the at least one first sensor device to be readjusted on the basis of density fluctuations.
- a monitoring of the discharge component 6 driven by the electric motor 7 can be represented by means of the characteristic curves or characteristic curve fields stored in the control device 15.
- torque curves that are characteristic of a specific degree of wear of the discharge component 6 can be stored in the memory unit 15b of the control in the direction 15, so that, for example, system defects can be detected.
- the method according to the invention can also be applied in a corresponding manner to the in Figure 3
- the system shown can be used for yield measurement.
- ⁇ b> List of reference symbols ⁇ /b> 1 container 36 Chopping and distributing device 2 Bulk material 37 Cross screw conveyor 3 Conveyor 38 Grain elevator 4th Cross conveyor component 39 Grain tank 5 Vertical conveyor component 40 Driver's cab 6th Discharge component 41 Grain tank outlet pipe 7th Electric motor 8th frequency converter 9 sensor 10 Speed sensor 11 First sensor device 12th Humidity sensor 13th Level sensor 14th Level sensor 15th Control device 15a Processor unit 15b Storage unit 15c Input-output interface 15d Input-output interface 16 Bus system 17th Input-output device 18th First sensor device 20th Yield measurement system 30th Harvester 31 Crop 32 Attachment 33 Threshing device 34 Separation device 35 Cleaning device
Landscapes
- Physics & Mathematics (AREA)
- Fluid Mechanics (AREA)
- General Physics & Mathematics (AREA)
- Life Sciences & Earth Sciences (AREA)
- Environmental Sciences (AREA)
- Filling Or Emptying Of Bunkers, Hoppers, And Tanks (AREA)
Description
- Die vorliegende Erfindung betrifft ein System zur Ertragsmessung gemäß dem Oberbegriff des Anspruches 1. Weiterhin betrifft die Erfindung ein Verfahren zum Betreiben eines Systems zur Ertragsmessung gemäß dem Anspruch 7 sowie ein landwirtschaftliches Arbeitsfahrzeug gemäß dem Anspruch 14.
- Systeme zur Ertragsmessung kommen insbesondere bei landschaftlichen Arbeitsfahrzeugen zum Einsatz, um die Menge eines während eines Ernteprozesses aufgenommenen schüttgutförmigen Erntegutes je Flächeneinheit zu bestimmen. Bei einem landwirtschaftlichen Arbeitsfahrzeug kann es sich beispielsweise um eine selbstfahrende Erntemaschine mit einem Behältnis zur Aufnahme von Schüttgut handeln oder um ein von einem Traktor gezogenes Transportfahrzeug mit einem Behälter, wie einen Überladewagen. Die Ertragsmessung wird unter anderem von einem landschaftlichen Betrieb zur internen betriebswirtschaftlichen Auswertung herangezogen oder von einem mit dem Ernteprozess beauftragten Lohnunternehmen zu Zwecken der Abrechnung verwendet.
- Ein solches System zur Ertragsmessung umfasst ein Behältnis zur Aufnahme von insbesondere agrarwirtschaftlichem, Schüttgut, eine zumindest eine Förderkomponente umfassende Fördervorrichtung zur Zuführung von Schüttgut in das Behältnis, zumindest eine erste Sensoreinrichtung zur Bestimmung des Volumens oder des Gewichts des durch die Fördervorrichtung in das Behältnis geförderten Schüttgutes, sowie eine Steuereinrichtung, die zur Auswertung der Signale der zumindest einen ersten Sensoreinrichtung eingerichtet ist.
- Ein System zur Ertragsmessung sowie ein Verfahren zum Betreiben eines Systems zu Ertragsmessung sind aus der
EP 2 960 634 A1 bekannt. DieEP 2 960 634 A1 beschreibt einen Behälter zur Aufnahme von Schüttgut, dem von einer Fördervorrichtung Schüttgut zugeführt wird. Das aus der Fördervorrichtung austretende Schüttgut wird von einem Massendurchsatzsensor erfasst. Der Massendurchsatzsensor ist als Wägezelle ausgeführt. Zur Erhöhung der Messgenauigkeit des Massendurchsatzsensors sind unterhalb des Behälters Akkumulationssensoren angeordnet. Durch die Akkumulationssensoren wird die Anhäufung des Schüttgutes im Behälter während des Befüllvorganges periodisch überwacht, wodurch das Maß bestimmt wird, mit dem sich das Gewicht des Schüttkegels verändert. Das Signal der Akkumulationssensoren wird von einer Steuereinrichtung herangezogen, um einen Kalibrierungsfaktor zu bestimmen, der auf den Massendurchsatzsensor anwendbar ist. - Die
WO2012088405 A1 beschreibt eine Vorrichtung und ein Verfahren mit den Merkmalen des Oberbegriffes der Ansprüche 1 und 7. Ausgehend von diesem Stand der Technik besteht die Aufgabe der Erfindung darin, ein System zur Ertragsmessung sowie ein Verfahren zum Betreiben eines Systems zur Ertragsmessung bereitzustellen, welches sich durch einen einfacheren Aufbau auszeichnet. - Diese Aufgabe wird durch ein System zur Ertragsmessung gemäß dem Anspruch 1 sowie ein Verfahren zum Betreiben eines Systems zur Ertragsmessung gemäß dem Anspruch 7 gelöst.
- Vorteilhafte Weiterbildungen sind Gegenstand der hiervon abhängigen Unteransprüche.
- Gemäß dem Anspruch 1 wird ein System zur Ertragsmessung vorgeschlagen, umfassend ein Behältnis zur Aufnahme von Schüttgut, eine zumindest eine Förderkomponente umfassende Fördervorrichtung zur Zuführung von Schüttgut in das Behältnis, zumindest eine erste Sensoreinrichtung zur Bestimmung des Volumens oder des Gewichts des durch die Fördervorrichtung in das Behältnis geförderten Schüttgutes, sowie eine Steuereinrichtung, die zur Auswertung der Signale des zumindest ein ersten Sensors eingerichtet ist. Die zur Ertragsmessung verwendete erste Sensoreinrichtung kann auf dem Funktionsprinzip der Volumenstrommessung, welche insbesondere berührungslos erfolgen kann, oder einer Kraft-/Impulsmessung basieren. Im letzteren Fall wird daraus der Massenstrom bestimmt. Um das System zur Ertragsmessung zu vereinfachen, wird erfindungsgemäß vorgeschlagen, dass zumindest eine Förderkomponente durch einen Elektromotor antreibbar ist und dass der Fördervorrichtung zumindest eine weitere Sensoreinrichtung zur Messung wenigstens einer physikalischen Größe des Elektromotors zugeordnet ist, mittels derer ein von der Förderkomponente aufgenommenes Drehmoment durch die Steuereinrichtung bestimmbar ist. Das von der Förderkomponente aufgenommene Drehmoment respektive der Drehmomentverlauf korrelieren mit der von der Förderkomponente geförderten Masse des Schüttgutes. D. h., die Bestimmung des von der Förderkomponente aufgenommenen Drehmomentes ist zur Ertragsmessung durch eine geeignete Signalauswertung heranziehbar. Durch eine kontinuierliche Bestimmung des Drehmomentes lassen sich zudem Schwankungen der Ertragsdichte eines Feldes, d.h. dem Ertrag pro Quadratmeter, die beispielsweise auf eine ungleichmäßige Düngung, Witterungseinflüsse oder dergleichen zurückzuführen sein können, kompensieren. Dadurch lässt sich die Genauigkeit der Ertragsmessung auch bei Schwankungen der Ertragsdichte innerhalb eines Feldes erhöhen. Darüber hinaus werden die mittels des durch die Steuereinrichtung bestimmten Drehmomentes Messwerte für die von der Förderkomponente geförderten Masse zur Kalibrierung des ersten Sensors herangezogen. Somit ergeben sich gegenüber dem aus der
EP 2 960 634 A1 undWO2012088405A1 bekannten System zur Ertragsmessung zumindest zwei signifikante Vorteile. Zum einen kann auf die Anordnung von dem Behältnis zur Aufnahme von Schüttgut zugeordneten Akkumulationssensoren verzichtet werden, zum anderen bietet die Verwendung eines Elektromotors zum Antreiben der zumindest einen Förderkomponente der Fördervorrichtung aufgrund der guten Regelbarkeit des Elektromotors Vorteile bei deren Betrieb. - Mit anderen Worten stellt sich durch die Verwendung des Elektromotors zum Antreiben der zumindest einen Förderkomponente der Fördervorrichtung ein Synergieeffekt ein, nämlich die Vereinfachung der Kalibrierung der Ertragsmessung.
- Die durch den Elektromotor angetriebene Förderkomponente ist die Komponente der Fördervorrichtung, aus welcher das Schüttgut unmittelbar in das Behältnis austritt bzw. an das Behältnis übergeben wird. Ein elektromotorischer Antrieb einer oder mehrerer Komponenten der Fördervorrichtung ist selbstverständlich denkbar, um in entsprechender Weise das aufgenommene Drehmoment zumindest einer dieser elektromotorisch angetriebenen Komponenten bestimmen zu können.
- Die Steuereinrichtung ist dazu eingerichtet in Abhängigkeit von einem erfassten Füllstand des Schüttgutes im Behältnis die Messung der wenigstens einen physikalischen Größe des Elektromotors durchzuführen. Hierzu kann die Messung der wenigstens einen physikalischen Größe innerhalb eines Füllstandintervalls erfolgen, welches einem definierten Volumen des von dem Behälter aufgenommenen Schüttgutes entspricht. In der Regel ist in dem Behältnis zumindest ein Füllstandsensor zugeordnet, welcher das jeweilige Erreichen eines prozentualen Anteils des maximalen Füllstands einer Bedienperson signalisiert. Der zumindest eine Füllstandsensor kann beispielsweise als optischer Sensor oder als mechanischer Sensor ausgeführt sein. Bevorzugt kommen zumindest zwei Füllstandsensoren zum Einsatz. Somit kann das Erreichen eines ersten, niedrigeren Füllstandes, welcher von einem ersten Füllstandsensor erfasst wird, den Beginn der Messung der wenigstens einen physikalischen Größe markieren. Mit dem hierzu zeitlich versetzten Erreichen des zweiten, höheren Füllstandes, welcher von einem zweiten Füllstandsensor erfasst wird, wird das Ende der Messung der wenigstens einen physikalischen Größe gekennzeichnet. Innerhalb dieses Füllstandintervalls wird von der Fördervorrichtung ein definiertes Volumen in das Behältnis gefördert. Das innerhalb des Füllstandintervalls geförderte Volumen sowie der innerhalb des Füllstandintervalls durch Messung der zumindest einen physikalischen Größe bestimmte Drehmomentverlauf können als automatischer Justage- bzw. Kalibrierwert für die Ertragsmessung für die zumindest eine erste Sensoreinrichtung verwendet werden.
- Vorteilhaft ist es, wenn die Steuereinrichtung zur Durchführung einer Initialmessung der wenigstens einen physikalischen Größe des Elektromotors im lastfreien Zustand der Fördervorrichtung eingerichtet ist. Während der Initialmessung wird durch die Messung der wenigstens einen physikalischen Größe das Drehmoment bestimmt, welches die durch den Elektromotor angetriebene Förderkomponente aufnimmt, wenn von dieser kein Schüttgut gefördert wird. Hierdurch lässt sich die Genauigkeit des Kalibriervorganges erhöhen. So kann durch die Initialmessung beispielsweise das durch Reibung zwischen der Förderkomponente und dessen Lagerung hervorgerufene Leerlastmoment bestimmt werden. Die Steuereinrichtung kann zur automatischen Durchführung der Initialmessung innerhalb von Zeitfenstern eingerichtet sein, wenn sich die Fördervorrichtung in einem Betriebszustand befindet, innerhalb dessen das Fördern von Schüttgut nicht durchgeführt wird. Dies kann beispielsweise bei einem als Mähdrescher ausgeführten landwirtschaftlichen Arbeitsfahrzeug dann der Fall sein, wenn diese sich unmittelbar vor der Aufnahme eines Erntebetriebes befindet. Weitere beispielhafte Betriebszustände können das Abtanken bei Stillstand des Mähdreschers oder Vorgewendefahrten sein. Derartige Betriebssituationen können von der Steuereinrichtung anhand von internen und externen Betriebsparametern des landwirtschaftlichen Arbeitsfahrzeugs bestimmt werden. Der Vorgang der Initialmessung lässt sich auch manuell von einer Bedienperson starten.
- Insbesondere kann die Steuereinrichtung zur Hinterlegung von Kennlinien oder Kennlinienfeldern für Drehmomentverläufe der durch den Elektromotor angetriebenen zumindest einen Förderkomponente der Fördervorrichtung eingerichtet sein. Hierzu umfasst die Steuereinrichtung zumindest eine Prozessoreinheit, zumindest eine Speichereinheit sowie Eingabe-Ausgabe-Schnittstellen. Die in der zumindest einen Speichereinheit hinterlegbaren Kennlinien oder Kennlinienfelder können fruchtartspezifisch sein, was insbesondere für das jeweilige Gewicht bzw. die jeweilige Dichte des Schüttgutes von Bedeutung sein kann, und/oder unterschiedliche Feuchtigkeitsgehalt des Schüttgutes berücksichtigen. Das von der Förderkomponente aufgenommene Drehmoment ist ein Maß für das Gewicht des transportierten Schüttgutes. Die jedoch unabhängig davon, ob von der Förderkomponente mehr Schüttgut, ein Schüttgut höherer Dichte oder sehr feuchtes Schüttgut transportiert wird. Diesem Umstand lässt sich durch die Kenntnis des geförderten Volumens innerhalb des Füllstandintervalls Rechnung tragen. Die Kennlinien oder Kennlinienfelder bilden den Zusammenhang zwischen dem von der elektromotorisch angetriebenen Förderkomponente der Fördervorrichtung aufgenommenen Drehmoment und der Masse des Schüttgutes ab. Weiterhin bilden die hinterlegbaren Kennlinien oder Kennlinienfelder den Zusammenhang zwischen der jeweiligen Schüttgutart respektive Fruchtart des Erntegutes und dessen Feuchtigkeitswerten ab. Darüber hinaus können auch Kennlinien oder Kennlinienfelder hinterlegbar sein, welche Drehmomentverläufe enthalten, die sich aufgrund von Verschleiß der zumindest einen elektromotorisch angetriebenen Förderkomponente der Fördervorrichtung einstellen können. Dadurch ließen sich im Zuge der Bestimmung des von der Förderkomponente aufgenommenen Drehmomentes Systemdefekte bzw. Einschränkungen der elektromotorisch angetriebenen Förderkomponente detektieren. Dies kann insbesondere während einer Initialmessung erfolgen.
- Zur Bestimmung des aufgenommenen Drehmomentes kann die zumindest eine weitere Sensoreinrichtung zur Messung von Strom als wenigstens eine physikalische Größe eingerichtet sein. Die Bestimmung des Drehmoments kann indirekt durch die Messung des Stroms bei konstanter Spannung oder aber durch Strom- und Spannungsmessung bei variabler Spannung erfolgen, da der Strom proportional zum Drehmoment ist. Die Messwerte für den Strom und die Spannung können zudem zur Berechnung einer von dem Elektromotor abgegebenen elektrischen Leistung durch die Steuereinrichtung herangezogen werden. Die Antriebsdrehzahl des Elektromotors wird zu dessen Regelung gemessen, beispielsweise mit einem Resolver oder einem Hall-Sensor.
- Bevorzugt kann die Steuereinrichtung dazu eingerichtet sein, den Elektromotor mittels eines Frequenzumrichters in Abhängigkeit von zumindest einem Betriebsparameter der Fördervorrichtung anzusteuern. Ein Betriebsparameter kann beispielsweise der Durchsatz der Fördervorrichtung sein. Neben einer durchsatzabhängigen Antriebsgeschwindigkeit der zumindest einen Förderkomponente der Fördervorrichtung lassen sich auch ein sanftes Anlaufen sowie Abbremsen der Förderkomponente darstellen. Die durchsatzabhängige Ansteuerung der Antriebsgeschwindigkeit der Förderkomponente hat den Vorteil, dass der Verschleiß gemindert sowie das Geräuschniveau der Fördervorrichtung herabgesetzt werden können. Weitere Betriebsparameter der Fördervorrichtung können die Feuchtigkeit oder eine Bruchgefahr des Schüttgutes sein. Beides wirkt sich bei einer zu hohen Fördergeschwindigkeit der Förderkomponente nachteilig auf die Qualität des Schüttgutes aus. Ein weiterer Vorteil ergibt sich daraus, dass der Frequenzumrichter bereits entsprechende Strom- und/oder Spannungssignale bereitstellt, die von der Steuereinrichtung auswertbar sind. Die Notwendigkeit, dem Behältnis zusätzliche Sensoren zur Bestimmung dieser physikalischen Größen zuzuordnen, wie es im eingangs genannten Stand der Technik der Fall ist, entfällt.
- Weiterhin kann das System einen Feuchtigkeitssensor zur Bestimmung der Feuchtigkeit des von der Fördervorrichtung geförderten Schüttgutes umfassen. Ein solcher Sensor dient dazu, die Feuchtigkeit im Schüttgut zu detektieren, um das tatsächliche Gewicht, das heißt die Trockenmasse, des von dem Behältnis aufgenommenen Schüttgutes bestimmen zu können. Zur Kalibrierung des Feuchtigkeitssensors kann ebenfalls die Bestimmung des Drehmomentverlaufs während eines Füllstandintervalls herangezogen werden. Das innerhalb des Füllstandintervalls geförderte Volumen sowie der innerhalb des Füllstandintervalls bestimmte Drehmomentverlauf können als automatischer Justage- bzw. Kalibrierwert für die Feuchtigkeitsmessung durch den Feuchtigkeitssensors verwendet werden.
- Weiterhin wird die Aufgabe durch ein Verfahren zum Betreiben eines Systems zur Ertragsmessung gemäß dem nebengeordneten Anspruch 7 gelöst.
- Der nebengeordnete Anspruch 7 schlägt ein Verfahren zum Betreiben eines Systems Ertragsmessung vor, wobei von einer zumindest eine Förderkomponente umfassenden Fördervorrichtung einem Behältnis Schüttgut zugeführt wird, dessen Gewicht oder Volumen mittels einer Steuereinrichtung durch eine Auswertung von Signalen zumindest einer ersten Sensoreinrichtung bestimmt wird. Das Verfahren ist dadurch gekennzeichnet, dass zumindest eine Förderkomponente der Fördervorrichtung elektromotorisch angetrieben wird, wobei zur Kalibrierung der Ertragsmessung ein von der Fördervorrichtung aufgenommenes Drehmoment durch Messung wenigstens einer physikalischen Größe des Elektromotors mittels zumindest einer weiteren Sensoreinrichtung bestimmt wird. Die von der Förderkomponente respektive der Fördervorrichtung geförderte Schüttgutmasse korreliert mit dem von der Förderkomponente aufgenommenen Drehmoment. Durch das erfindungsgemäße Verfahren lässt sich eine initiale Kalibrierung der ersten Sensoreinrichtung durchführen, welche bei jedem erneuten Ernteeinsatz erneut durchführbar ist.
- Dabei können die Messungen wenigstens einen der physikalischen Größe innerhalb zumindest eines Füllstandintervalls durchgeführt werden. Eine Füllstandüberwachung der Schüttgüter aufnehmenden Behältnisses wird im Allgemeinen durch zumindest einen dem Behältnis zugeordneten Füllstandsensor realisiert. Der zumindest eine dem Behältnis zugeordnete Füllstandsensor ist mit der Steuereinrichtung signaltechnisch verbunden, um Füllstanddaten an diese zur Auswertung zu übermitteln. Wird während des Befüllens des Behältnisses ein erster Schwellwert erreicht bzw. passiert, kann die Messung der zumindest einen physikalischen Größe zur Bestimmung des Drehmoments durch die Steuereinrichtung automatisch initiiert werden. Mit dem Erreichen eines zweiten Schwellwertes des Füllstandes wird die Messung durch die Steuereinrichtung automatisch beendet. Das innerhalb des Füllstandintervalls von dem Behältnis aufgenommene Schüttgutvolumen wird zusammen mit der durch die Bestimmung des Drehmoments ermittelten Schüttgutmasse als automatischer Justagewert für die Ertragsmessung verwendet.
- Bevorzugt kann eine Initialmessung der wenigstens einen physikalischen Größe des Elektromotors in einem lastfreien Zustand der Fördervorrichtung durchgeführt werden. Auf diese Weise lässt sich das erforderliche Drehmoment der zumindest einen elektromotorisch angetriebenen Förderkomponente bestimmen, welche auf Reibung zwischen der Förderkomponente und deren Lagerung zurückzuführen ist. Hierdurch lässt sich die Genauigkeit des Verfahrens erhöhen. Zur Durchführung der Initialmessung können geeignete Betriebszustände der Fördervorrichtung genutzt werden, während der eine Förderung von Schüttgut durch die Fördervorrichtung nicht zu erwarten ist. Solche Betriebszustände können durch eine Bedienperson bestimmt werden, durch welche eine Initialmessung manuell ausgelöst wird. Alternativ können solche Betriebszustände durch die Steuereinrichtung anhand von bereitgestellten internen und externen Betriebsparametern bestimmt werden, so dass von der Steuereinrichtung die Initialmessung automatisiert ausgelöst werden kann.
- Vorteilhaft ist es, dass die Initialmessung der wenigstens einen physikalischen Größe des Elektromotors während des laufenden Betriebes der Fördervorrichtung wiederholt durchgeführt werden kann. Auf diese Weise lassen sich Parameteränderungen, welche Einfluss auf den Betrieb der Fördervorrichtung haben können, berücksichtigen. Hierzu kann von der Steuereinrichtung das Auftreten eines zur wiederholten Durchführung der Initialmessung geeigneten Betriebszustandes erfasst werden.
- Insbesondere kann zur Bestimmung des von der zumindest einen Förderkomponente aufgenommenen Drehmomentes zumindest der Strom gemessen und ausgewertet wird. Die Messung des Stroms bei konstanter Spannung oder des Stroms und der Spannung bei variabler Spannung hat den Vorteil, dass diese mit weniger messtechnischem Aufwand realisierbar sind. Ein zur Ansteuerung des Elektromotors vorgesehener Frequenzumrichter stellt entsprechende Signale für den Strom und die Spannung als physikalische Größen bereit. Ein Drehmomentsensor, welcher der wenigstens einen Förderkomponente zugeordnet wird, kann somit entfallen. Das von der Förderkomponente aufgenommene Drehmoment wird, da stets proportional zum Strom, indirekt durch die Strommessung bestimmt.
- Weiterhin wird die Feuchtigkeit des von der Fördervorrichtung beförderten Schüttgutes bestimmt. Eine Kalibrierung eines hierfür vorgesehenen Feuchtigkeitssensors kann in der Kalibrierung der Ertragsmessung entsprechender Weise durchgeführt werden. In Kenntnis der innerhalb eines Füllstandintervalls geförderten Schüttgutmenge und des Schüttgutvolumens kann sich bei bekannter Dichte des Schüttgutes auf die Feuchtigkeit schließen lassen.
- Gemäß einer vorteilhaften Weiterbildung kann mittels der Steuereinrichtung eine Kennlinie oder ein Kennlinienfeld für einen Drehmomentverlauf der Förderkomponente erstellt werden. Hierzu kann die Art des Schüttgutes der Steuereinrichtung vorgegeben und können die Messverläufe der Feuchtigkeitsmessung, der Strommessung sowie der Gewichts- oder Volumenmessung von der Steuereinrichtung aufgezeichnet und ausgewertet werden. Hierzu kann die Steuereinrichtung entsprechend eingerichtet sein.
- Des Weiteren wird ein landwirtschaftliches Arbeitsfahrzeug vorgeschlagen, gekennzeichnet durch ein System zur Ertragsmessung nach einem der Ansprüche 1 bis 7, wobei das landwirtschaftliche Arbeitsfahrzeug zur Durchführung eines Verfahrens nach einem der Ansprüche 8 bis 14 eingerichtet ist. Als elektromotorisch angetriebene Förderkomponente kommt beispielsweise bei einem als Mähdrescher ausgebildeten landwirtschaftlichen Arbeitsfahrzeug die Korntankauslaufschnecke in Betracht. Denkbar ist auch der elektromotorische Antrieb des sogenannten Kornelevators.
- Die vorliegende Erfindung wird nachstehend anhand von in den Zeichnungen dargestellten Ausführungsbeispielen näher erläutert.
- Es zeigen:
- Fig. 1
- eine schematische Ansicht eines landwirtschaftlichen Arbeitsfahrzeugs mit einem Behältnis zur Aufnahme von Schüttgut;
- Fig. 2
- eine schematische Ansicht eines Systems zur Ertragsmessung;
- Fig. 3
- eine schematische Ansicht eines Behältnisses mit einer Fördervorrichtung gemäß einer weiteren Ausführungsform;
- Fig. 4
- eine schematische Darstellung einer Steuereinrichtung des Systems zur Ertragsmessung.
- In
Fig. 1 ist eine schematische Ansicht eines als Mähdrescher 30 ausgeführten landwirtschaftlichen Arbeitsfahrzeugs mit einem als Korntank 39 ausgebildeten Behältnis zur Aufnahme von schüttgutförmigen Erntegut dargestellt. Zur Aufnahme von Erntegut 31 weist der Mähdrescher 30 ein als Schneidwerk ausgeführtes Vorsatzgerät 32 auf. Das von dem Vorsatzgerät 32 abgeerntete Erntegut 31 wird einer Dreschvorrichtung 33 zugeführt, in welcher das Erntegut 31 separiert wird. Die in der Dreschvorrichtung 33 abgeschiedenen Erntegutbestandteile, im Wesentlichen schüttgutförmiges Korn sowie Nichtkornbestandteile, werden einer Reinigungsvorrichtung 35 zugeführt, um das schüttgutförmige Korn von den Nichtkornbestandteilen zu trennen. Von der Reinigungsvorrichtung 35 wird das Korn einer Querförderschnecke 37 zugeführt, welche das Korn zu einem Kornelevator 38 fördert. Der Kornelevator 38 fördert das Korn mittels einer nicht dargestellten Korntankauslaufschnecke in den Korntank 39. Weiterhin umfasst der Mähdrescher 30 eine Abscheidevorrichtung 34, eine Häcksel- und Verteilvorrichtung 36 sowie eine Fahrerkabine 40. Das im Korntank 39 gebunkerte Korn wird durch ein Korntankauslaufrohr 41 auf einen Ladewagen zum Abtransport überladen. - In
Figur 2 ist eine schematische Ansicht eines Systems 20 zur Ertragsmessung dargestellt, umfassend ein Behältnis 1 mit einer Fördervorrichtung 3. Bei dem Behältnis 1 kann es sich um den Korntank 39 und bei der Fördervorrichtung 3 um die Querförderschnecke 37, den Kornelevator 38 sowie die nicht dargestellte Korntankauslaufschnecke des Mähdreschers 30 handeln. Das Behältnis 1 dient der Aufnahme von Schüttgut 2, insbesondere Korn. Die Fördervorrichtung 3 umfasst zumindest eine Förderkomponente. In dem dargestellten Ausführungsbeispiel umfasst die Fördervorrichtung 3 mehrere Förderkomponenten, eine Querförderkomponente 4, eine Vertikalförderkomponente 5 sowie eine Abförderkomponente 6. Von der Querförderkomponente 4 wird Schüttgut an die Vertikalförderkomponente 5 gefördert, welche das Schüttgut in im Wesentlichen vertikaler Richtung der Abförderkomponente 6 zuführt, die das Schüttgut in das Behältnis 1 abfördert. Die Abförderkomponente 6 ist im dargestellten Ausführungsbeispielen als Schneckenförderer ausgebildet. Der Antrieb zumindest der Abförderkomponente 6 erfolgt durch einen Elektromotor 7. Der Elektromotor 7 ist mittels eines Frequenzumrichters 8 ansteuerbar. Der Frequenzumrichter 8 weist zumindest einen Sensor 9 zur Messung des Stroms und/oder der Spannung auf. Der Elektromotor 7 ist mit einem als Hall-Sensor oder Resolver ausgeführten Drehzahlsensor 10 ausgestattet. Die gute Regelbarkeit der elektromotorisch angetriebenen Abförderkomponente 6 bietet verschiedene Vorteile, wie z.B. ein sanftes Anlaufen sowie Stoppen der Abförderkomponente 6 oder eine durchsatzabhängige Geschwindigkeitsregelung der Abförderkomponente 6, um den Komponentenverschleiß und das Geräuschniveau herabzusetzen. Darüber hinaus lässt sich die Gefahr einer Beschädigung des Schüttgutes, z.B. die Bruchkorngefahr, durch eine entsprechende Geschwindigkeitsregelung reduzieren. - Das System 20 zur Ertragsmessung weist eine der Fördervorrichtung 3 zugeordnete erste Sensoreinrichtung 11 auf, welche der Bestimmung des Gewichts oder des Volumens des von der Fördervorrichtung 3 geförderten Schüttgutes 2 dient. Die erste Sensoreinrichtung 11 kann berührungslos arbeiten, um das von der Vertikalförderkomponente 5 geförderte Schüttgutvolumen zu bestimmen. Hierzu kann die erste Sensoreinrichtung 11 beispielsweise in Form einer Lichtschranke ausgestaltet sein, wie sie aus der
EP 0 931 445 A1 bekannt ist. Alternativ kann die Sensoreinrichtung 11 auch als eine Kraftmesszelle ausgebildet sein, um das Gewicht des geförderten Schüttgutes 2 zu bestimmen. Weiterhin ist der der Fördervorrichtung 3 ein Feuchtigkeitssensor 12 zugeordnet, mit dem kontinuierlich die Feuchtigkeit des Schüttgutes 2 gemessen wird. - Im Inneren des Behältnisses 1 ist zumindest ein Füllstandsensor angeordnet, in dem in
Figur 2 dargestellten Ausführungsbeispiel sind zwei Füllstandsensoren 13, 14 vorgesehen, welche als mechanische Taster ausgebildet sind. Der zumindest eine Füllstandsensor kann auch als ein optischer Sensor ausgebildet sein. Der eine Füllstandsensor 13 ist in der Nähe des Bodens an einer Seitenwand des Behältnisses 1 angeordnet, während der andere Füllstandsensor 14 hierzu beabstandet im oberen Bereich der Seitenwand des Behältnisses 1 angeordnet ist. Die Positionierung der Füllstandsensoren 13 und 14 ist derart gewählt, dass sich zwischen diesen ein definiertes Volumen einstellt. So kann die Position des Füllstandsensors 13 einem Füllstand des Behältnisses 1 von beispielsweise 30 % entsprechen, während die Position des Füllstandsensors 14 einem Füllstand des Behältnisses 1 von beispielsweise 70 % entspricht. Hiervon abweichende Positionierungen der Füllstandsensoren sind denkbar. - Das System 20 zur Ertragsmessung umfasst eine Steuereinrichtung 15, welche durch ein Bussystem 16 mit dem Sensor 9 des Frequenzumrichters 8, dem Drehzahlsensor 10, der ersten Sensoreinrichtung 11, dem Feuchtigkeitssensor 12 sowie den Füllstandsensoren 13 und 14 signaltechnisch verbunden ist. Mit dem Bezugszeichen 17 ist eine Eingabe-Ausgabevorrichtung bezeichnet welche ebenfalls durch das Bussystem 16 mit der Steuereinrichtung 15 verbunden ist. Die Eingabe-Ausgabevorrichtung 17 ermöglicht es einer Bedienperson mit der Steuereinrichtung 15 zu interagieren.
- In
Figur 3 ist eine schematische Ansicht des Behältnisses mit der Fördervorrichtung 3 gemäß einer weiteren Ausführungsform dargestellt. Im Unterschied zu der vorangehend beschriebenen Ausführungsform ist als eine erste Sensoreinrichtung 18 eine Kraftmesszelle zur Kraft-/Impulsmessung vorgesehen, um das von der Fördervorrichtung 3 geförderte Gewicht des Schüttgutes 2 zu bestimmen. Auch diese erste Sensoreinrichtung 18 ist durch das Bussystem 16 mit der Steuereinrichtung 15 signaltechnisch verbunden. Im Übrigen unterscheidet sich der Aufbau des Systems 20 zur Ertragsmessung nicht von dem inFigur 2 dargestellten. - In
Figur 4 ist die Steuereinrichtung 15 des Systems 20 zur Ertragsmessung gemäß den vorstehend beschriebenen Ausführungsformen schematisch dargestellt. Die Steuereinrichtung 15 umfasst zumindest eine Prozessoreinheit 15a, wenigstens eine Speichereinheit 15b, sowie eine oder mehrere Eingabe-Ausgabe-Schnittstellen 15c, 15d. In der wenigstens einen Speichereinheit 15b sind Kennlinien oder Kennlinienfelder für Drehmomentverläufe zumindest der von dem Elektromotor 7 angetriebenen Abförderkomponente 6 hinterlegbar. Mittels der Eingabe-Ausgabe-Schnittstellen 15c, 15d empfängt die Steuereinrichtung 15 jeweils die Messwerte der ersten Sensoreinrichtung 11 bzw. 18 sowie des Feuchtigkeitssensors 12 und der Füllstandsensoren 13 und 14. - Nachstehend wird der Verfahrensablauf anhand des in
Figur 2 dargestellten Ausführungsbeispieles erläutert. Das von der Abförderkomponente 6 aufgenommene Drehmoment korreliert mit der durch die Abförderkomponente 6 geförderten Masse des Schüttgutes 2. Somit wird durch die Bestimmung des von der Abförderkomponente 6 aufgenommenen Drehmomentes eine Ertragsmessung möglich. Das Drehmoment ist proportional zum Strom, welcher durch den Sensor 9 des Frequenzumrichters 8 kontinuierlich gemessen wird. Anhand der in der wenigstens einen Speichereinheit 15b hinterlegten Kennlinien bzw. Kennlinienfelder der Drehmomentverläufe lässt sich einem jeweils bestimmten Drehmoment eine Masse des Schüttgutes 2 zuordnen. Denkbar ist auch die direkte Messung des Drehmoments mittels eines Drehmomentsensors. - Zur Kalibrierung der ersten Sensoreinrichtung 11 ist es erfindungsgemäß vorgesehen, dass die Bestimmung des Drehmoments bzw. des Drehmomentverlaufes innerhalb eines Füllstandintervalls erfolgt. Beginn und Ende des Füllstandintervalls werden durch die Füllstandsensoren 13 und 14 detektiert. Wird durch die Befüllung des Behältnisses 1 der Füllstandsensor 13 aktiviert, so wird das entsprechende Signal des Füllstandsensors 13 von der Steuereinrichtung 15 verarbeitet, um den Messvorgang zur Bestimmung des Drehmoments automatisch zu starten. Erreicht der Füllstand im Behältnis 1 eine Höhe, welche den Füllstandsensor 14 aktiviert, so wird das entsprechende Signal des Füllstandsensors 13 von der Steuereinrichtung 15 verarbeitet, um den Messvorgang automatisch zu beenden.
- Die innerhalb des Füllstandintervalls dem Behältnis 1 durch die Abförderkomponente 6 zugeführte Schüttgutmasse lässt sich mittels der in der Speichereinheit 15b hinterlegten Kennlinien bzw. Kennlinienfelder von Drehmomentverläufen bestimmen. Anhand der Kennlinien bzw. Kennlinienfelder wird von der Steuereinrichtung 15 einem Drehmoment eine Masse zugeordnet. Das zwischen den Füllstandsensoren 13 und 14 bekannte definierte Volumen wird zusammen mit der aus dem Drehmoment bestimmten Masse automatisch als Justagewert für die Ertrags- und die Feuchtemessung verwendet. Mit diesem Justagewert ist es möglich, eine kontinuierliche Kompensation von Dichteschwankungen vorzunehmen, die während der Zuführung von Schüttgut 2 in das Behältnis 1 auftreten können. So können beim Ernten eines agrarwirtschaftlichen Produktes innerhalb eines abzuerntenden Feldes Ertragsschwankungen auftreten, unter anderem die auf eine ungleichmäßige Bestandsdichte zurückzuführen sind.
- Um eine Erhöhung der Genauigkeit des Verfahrens zu erreichen, findet zumindest eine Initialmessung statt, während der das von der Abförderkomponente 6 aufgenommene Drehmoment im lastfreien Zustand, d. h. ohne Schüttgut 2 zu fördern, bestimmt wird. Eine solche Initialmessung kann automatisch innerhalb bestimmter Zeitfenster durchgeführt werden, in denen kein Materialfluss in der Fördervorrichtung 3 vorliegt. So kann im Fall des Mähdreschers 30, auf welchem das erfindungsgemäße System 20 zur Ertragsmessung zum Einsatz kommen kann, direkt vor der Aufnahme des Erntebetriebes, beim Abtanken im Stillstand oder bei längeren vorgehende Fahrten durchgeführt werden. Die Durchführung der Initialmessung wird aber die Steuereinrichtung 15 initiiert.
- Ein weiterer Aspekt ist im Fall der Anwendung des Systems 20 an dem Mähdrescher 30, dass die als Korntankauslaufschnecke ausgebildete Abförderkomponente 6 der Fördervorrichtung 3 ab einem Füllstand oberhalb des Füllstandsensors 14 das schüttgutförmige Korn nicht mehr frei in den Korntank 39 werfen kann, sondern dies nach oben aufschiebt. Dies führt dazu, dass das Korn in der Korntankauslaufschnecke stärker verdichtet wird, sodass eine Kompensation der Dichteschwankung unter Umständen nicht mehr mit hinreichender Genauigkeit möglich ist. Mit dem Passieren einer Füllstandobergrenze erfolgt die Kompensation der Dichteschwankung anhand des letzten ermittelten Justagewertes.
- Das Verfahren zum Betreiben des Systems 20 zur Ertragsmessung ist besonders vorteilhaft, da das Verfahren ohne großen Aufwand wiederholt durchgeführt werden kann. Hierdurch lässt sich eine Nachjustage der zumindest einen ersten Sensoreinrichtung aufgrund von Dichteschwankungen durchführen.
- Mittels der in der Steuereinrichtung 15 hinterlegten Kennlinien bzw. Kennlinienfelder lässt sich eine Überwachung der durch den Elektromotor 7 angetriebenen Abförderkomponente 6 darstellen. Hierzu können Drehmomentverläufe, die für einen spezifischen Grad an Verschleiß der Abförderkomponente 6 charakteristisch sind, in der Speichereinheit 15b der Steuer in Richtung 15 hinterlegt werden, sodass sich beispielsweise Systemdefekte detektieren lassen.
- Das erfindungsgemäße Verfahren ist in entsprechender Weise auch auf das in
Figur 3 dargestellte System zur Ertragsmessung anwendbar.Bezugszeichenliste 1 Behältnis 36 Häcksel- und Verteilvorrichtung 2 Schüttgut 37 Querförderschnecke 3 Fördervorrichtung 38 Kornelevator 4 Querförderkomponente 39 Korntank 5 Vertikalförderkomponente 40 Fahrerkabine 6 Abförderkomponente 41 Korntankauslaufrohr 7 Elektromotor 8 Frequenzumrichter 9 Sensor 10 Drehzahlsensor 11 Erste Sensoreinrichtung 12 Feuchtigkeitssensor 13 Füllstandsensor 14 Füllstandsensor 15 Steuereinrichtung 15a Prozessoreinheit 15b Speichereinheit 15c Eingabe-Ausgabe-Schnittstelle 15d Eingabe-Ausgabe-Schnittstelle 16 Bussystem 17 Eingabe-Ausgabevorrichtung 18 Erste Sensoreinrichtung 20 System zu Ertragsmessung 30 Mähdrescher 31 Erntegut 32 Vorsatzgerät 33 Dreschvorrichtung 34 Abscheidevorrichtung 35 Reinigungsvorrichtung
Claims (14)
- System (20) zur Ertragsmessung, umfassend:- ein Behältnis (1) zur Aufnahme von Schüttgut (2),- eine zumindest eine Förderkomponente (4, 5, 6) umfassende Fördervorrichtung (3) zur Zuführung von Schüttgut (2) in das Behältnis (1),- zumindest eine der Fördervorrichtung (3) zugeordnete erste Sensoreinrichtung (11, 18) zur Bestimmung des Volumens oder des Gewichts des durch die Fördervorrichtung (3) in das Behältnis (1) geförderten Schüttgutes (2),- eine Steuereinrichtung (15), die zur Auswertung der Signale der zumindest einen ersten Sensoreinrichtung (11, 18) eingerichtet ist,dadurch gekennzeichnet, dass
zumindest eine Förderkomponente (6) durch einen Elektromotor (7) antreibbar ist und dass der Fördervorrichtung (3) zumindest eine weitere Sensoreinrichtung (9) zur Messung wenigstens einer physikalischen Größe des Elektromotors (7) zugeordnet ist, mittels derer ein von der zumindest einen Förderkomponente (6) aufgenommenes Drehmoment durch die Steuereinrichtung (15) bestimmbar ist, wobei die Steuereinrichtung (15) dazu eingerichtet ist, in Abhängigkeit von einem erfassten Füllstand des Schüttguts (2) im Behältnis (1) die Messung der wenigstens einen physikalischen Größe des Elektromotors (7) durchzuführen, wobei das durch die Steuereinrichtung (15) bestimmte Drehmoment zur Kalibrierung der ersten Sensoreinrichtung (11, 18) herangezogen wird. - System (20) nach Anspruch 1, dadurch gekennzeichnet, dass die Steuereinrichtung (15) zur Durchführung einer Initialmessung der wenigstens einen physikalischen Größe des Elektromotors (7) im lastfreien Zustand der Fördervorrichtung (3) eingerichtet ist.
- System (20) nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die Steuereinrichtung (15) zur Hinterlegung von Kennlinien oder Kennlinienfeldern für Drehmomentverläufe der durch den Elektromotor (7) angetriebenen Förderkomponente (6) der Fördervorrichtung (3) eingerichtet ist.
- System (20) nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die zumindest eine weitere Sensoreinrichtung (9) zur Messung von Strom als wenigstens eine physikalische Größe eingerichtet ist.
- System (20) nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die Steuereinrichtung (15) dazu eingerichtet ist, den Elektromotor (7) mittels eines Frequenzumrichters (8) in Abhängigkeit von einem Betriebsparameter der Fördervorrichtung (3) anzusteuern.
- System (20) nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass das System (20) einen Feuchtigkeitssensor (12) zur Bestimmung der Feuchtigkeit des von der Fördervorrichtung (3) geförderten Schüttgutes (2) umfasst.
- Verfahren zum Betreiben eines Systems (20) zur Ertragsmessung, wobei von einer zumindest eine Förderkomponente (4, 5, 6) umfassenden Fördervorrichtung (3) einem Behältnis (1) Schüttgut (2) zugeführt wird, dessen Gewicht oder Volumen mittels einer Steuereinrichtung (15) durch eine Auswertung von Signalen zumindest einer der Fördervorrichtung (3) zugeordneten ersten Sensoreinrichtung (11, 18) bestimmt wird, dadurch gekennzeichnet, dass zumindest eine Förderkomponente (6) der Fördervorrichtung (3) elektromotorisch angetrieben wird, wobei zur Kalibrierung des Systems (20) zur Ertragsmessung ein von der Fördervorrichtung (3) aufgenommenes Drehmoment durch Messung wenigstens einer physikalischen Größe des Elektromotors (7) mittels zumindest einer weiteren Sensoreinrichtung (9) bestimmt wird.
- Verfahren nach Anspruch 7, dadurch gekennzeichnet, dass die Messungen der physikalischen Größe innerhalb zumindest eines Füllstandintervalls durchgeführt werden.
- Verfahren nach einem der Ansprüche 7 oder 8, dadurch gekennzeichnet, dass eine Initialmessung der wenigstens einen physikalischen Größe des Elektromotors (7) in einem lastfreien Zustand der Fördervorrichtung (3) durchgeführt wird.
- Verfahren nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die Initialmessung der wenigstens einen physikalischen Größe des Elektromotors (7) während des laufenden Betriebes der Fördervorrichtung (3) wiederholt durchgeführt wird.
- Verfahren nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass zur Bestimmung eines von der Fördervorrichtung (3) aufgenommenen Drehmomentes zumindest der Strom gemessen und ausgewertet wird.
- Verfahren nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die Feuchtigkeit des von der Fördervorrichtung (3) geförderten Schüttgutes (2) bestimmt wird.
- Verfahren nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass mittels der Steuereinrichtung (15) eine Kennlinie oder ein Kennlinienfeld für einen Drehmomentverlauf der zumindest einen Förderkomponente (6) erstellt wird.
- Landwirtschaftliches Arbeitsfahrzeug (30), gekennzeichnet durch ein System (20) zur Ertragsmessung nach einem der Ansprüche 1 bis 6, wobei das landwirtschaftliche Arbeitsfahrzeug (30) zur Durchführung eines Verfahrens nach einem der Ansprüche 7 bis 13 eingerichtet ist.
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE102017114405.6A DE102017114405A1 (de) | 2017-06-28 | 2017-06-28 | System zur Ertragsmessung und Verfahren zum Betreiben eines Systems zur Ertragsmessung |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP3420794A1 EP3420794A1 (de) | 2019-01-02 |
| EP3420794B1 true EP3420794B1 (de) | 2021-09-08 |
Family
ID=61768173
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP18163855.2A Active EP3420794B1 (de) | 2017-06-28 | 2018-03-26 | System zur ertragsmessung und verfahren zum betreiben eines systems zur ertragsmessung |
Country Status (2)
| Country | Link |
|---|---|
| EP (1) | EP3420794B1 (de) |
| DE (1) | DE102017114405A1 (de) |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102757823B1 (ko) * | 2015-12-25 | 2025-01-22 | 가부시끼 가이샤 구보다 | 콤바인 및 콤바인용 곡립 수량 관리 시스템 |
| CN112631279B (zh) * | 2020-12-09 | 2023-03-14 | 甘肃省机械科学研究院有限责任公司 | 一种青贮收获机喂入量控制系统及方法 |
| DE102023104330A1 (de) * | 2023-02-22 | 2024-08-22 | Claas Selbstfahrende Erntemaschinen Gmbh | Erntemaschine |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5318475A (en) * | 1992-06-19 | 1994-06-07 | Case Corporation | Apparatus for measuring mass flow of grain in a harvesting machine |
| DE19802756B4 (de) | 1998-01-26 | 2004-04-22 | Claas Selbstfahrende Erntemaschinen Gmbh | Fördervolumen-Meßvorrichtung eines Elevators, insbes. für Erntegut |
| ES2675393T3 (es) * | 2010-12-22 | 2018-07-11 | Precision Planting Llc | Métodos, sistemas y aparatos para monitorizar rendimiento y vehículo |
| US9645006B2 (en) | 2014-06-27 | 2017-05-09 | Deere & Company | Calibration of grain mass measurement |
-
2017
- 2017-06-28 DE DE102017114405.6A patent/DE102017114405A1/de not_active Withdrawn
-
2018
- 2018-03-26 EP EP18163855.2A patent/EP3420794B1/de active Active
Also Published As
| Publication number | Publication date |
|---|---|
| EP3420794A1 (de) | 2019-01-02 |
| DE102017114405A1 (de) | 2019-01-03 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP2829171B1 (de) | Selbstfahrende Erntemaschine und Fahrzeugverbund | |
| EP2702858B1 (de) | Erntemaschine mit Gutzufuhrregelung | |
| EP2995191B1 (de) | Verfahren zur steuerung eines überladeprozesses | |
| EP1847169B1 (de) | Verfahren und Vorrichtung zur Einstellung der Schnittlänge einer Häckseleinrichtung einer landwirtschaftlichen Erntemaschine | |
| EP3662741A1 (de) | Landwirtschaftliche arbeitsmaschine sowie verfahren zum betreiben einer landwirtschaftlichen arbeitsmaschine | |
| DE10134137B4 (de) | Selbstfahrende landwirtschaftliche Erntemaschine | |
| DE102013209197A1 (de) | Erntemaschine mit vorausschauender Vortriebsgeschwindigkeitsregelung | |
| EP1281310A1 (de) | Erntmaschine mit Geschwindigkeitssteuerung | |
| EP0728409A1 (de) | Verfahren zur automatischen Regelung wenigstens eines Abschnitts der Gutbearbeitung in einer Erntemaschine | |
| DE102005005556B4 (de) | Vorrichtung zur Steuerung einer landwirtschaftlichen Erntemaschine | |
| EP3420794A1 (de) | System zur ertragsmessung und verfahren zum betreiben eines systems zur ertragsmessung | |
| EP2168420B1 (de) | Landwirtschaftliche Erntemaschine | |
| EP4410089A1 (de) | Selbstfahrende landwirtschaftliche erntemaschine | |
| EP4154700A1 (de) | Erntemaschine mit bandschneidwerk | |
| AT401992B (de) | Verfahren zur überwachung des ladevorganges bei einem selbstladewagen | |
| EP4074160B1 (de) | Verfahren zum einstellen einer füllhöhe in einem behältnis | |
| EP4154697B1 (de) | Fahrerassistenzsystem einer erntemaschine mit bandschneidwerk | |
| DE102013005842A1 (de) | Landwirtschaftliche Erntemaschine | |
| AT517293B1 (de) | Verfahren und Steuerungseinrichtung zum Betreiben eines landwirtschaftlichen Ladewagens | |
| AT516970A2 (de) | Verfahren zum Betreiben eines landwirtschaftlichen Ladewagens und landwirtschaftlicher Ladewagen | |
| DE102014006001B4 (de) | Flüssigfütterungsanlage und Verfahren zur Flüssigfütterung | |
| DE202019104154U1 (de) | Lade- und/oder Häckselwagen | |
| EP4420506B1 (de) | Erntemaschine | |
| DE202021105701U1 (de) | Vorrichtung zur Steuerung einer Vorschubeinheit an Nutzfahrzeugen | |
| DE102022100195A1 (de) | Feldhäcksler |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| AX | Request for extension of the european patent |
Extension state: BA ME |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20190702 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: EXAMINATION IS IN PROGRESS |
|
| 17Q | First examination report despatched |
Effective date: 20190829 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20210407 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: REF Ref document number: 1427674 Country of ref document: AT Kind code of ref document: T Effective date: 20210915 Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: GERMAN |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 502018006915 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20210908 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20211208 Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20211208 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20211209 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20220108 Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20220110 Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: AL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 502018006915 Country of ref document: DE |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| 26N | No opposition filed |
Effective date: 20220609 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PL |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20220326 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20220331 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220326 Ref country code: LI Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220331 Ref country code: IT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220326 Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220326 Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220331 Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220331 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20220331 |
|
| P01 | Opt-out of the competence of the unified patent court (upc) registered |
Effective date: 20230516 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20180326 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MM01 Ref document number: 1427674 Country of ref document: AT Kind code of ref document: T Effective date: 20230326 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230326 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230326 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20210908 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20260319 Year of fee payment: 9 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: AT Payment date: 20260410 Year of fee payment: 5 |