EP2415558B1 - Handgehaltene Poliermaschine - Google Patents
Handgehaltene Poliermaschine Download PDFInfo
- Publication number
- EP2415558B1 EP2415558B1 EP11172636.0A EP11172636A EP2415558B1 EP 2415558 B1 EP2415558 B1 EP 2415558B1 EP 11172636 A EP11172636 A EP 11172636A EP 2415558 B1 EP2415558 B1 EP 2415558B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- planetary gear
- polishing machine
- drive motor
- hand
- machine according
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B23/00—Portable grinding machines, e.g. hand-guided; Accessories therefor
- B24B23/02—Portable grinding machines, e.g. hand-guided; Accessories therefor with rotating grinding tools; Accessories therefor
- B24B23/028—Angle tools
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B47/00—Drives or gearings; Equipment therefor
- B24B47/10—Drives or gearings; Equipment therefor for rotating or reciprocating working-spindles carrying grinding wheels or workpieces
- B24B47/12—Drives or gearings; Equipment therefor for rotating or reciprocating working-spindles carrying grinding wheels or workpieces by mechanical gearing or electric power
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25F—COMBINATION OR MULTI-PURPOSE TOOLS NOT OTHERWISE PROVIDED FOR; DETAILS OR COMPONENTS OF PORTABLE POWER-DRIVEN TOOLS NOT PARTICULARLY RELATED TO THE OPERATIONS PERFORMED AND NOT OTHERWISE PROVIDED FOR
- B25F5/00—Details or components of portable power-driven tools not particularly related to the operations performed and not otherwise provided for
- B25F5/001—Gearings, speed selectors, clutches or the like specially adapted for rotary tools
Definitions
- the invention relates to a hand-held polishing machine, comprising a drive motor, a drive motor shaft which is driven directly by the drive motor, a polishing tool shaft which is oriented transversely to the drive motor shaft, and a reduction gear which is coupled to the drive motor shaft and the polishing tool shaft and which has at least two stages is, wherein the reduction gear comprises a planetary gear as a reduction stage.
- the reduction gear serves to reduce the speed of the drive motor shaft provided by the drive motor to a speed of the polishing tool shaft which is suitable for polishing operations.
- a speed is in particular of the order of 3,500 rpm.
- a hand tool gear in particular for an angle grinder, with a rotatably mounted drive shaft that can be driven by an electric motor and a rotatably mounted output shaft for driving a tool.
- a planetary gear is provided for torque transmission from the input shaft to the output shaft.
- a hand-held power tool with a motor housing and a gear housing, with an electric drive motor having a motor shaft being arranged in the motor housing
- Gear housing a gear with an angular gear and a tool spindle are arranged, and wherein the tool spindle is at an at least approximately right angle to the motor shaft and from the motor shaft is driven by the gearbox.
- the gear has a planetary gear.
- the invention is based on the object of providing a hand-held polishing machine of the type mentioned at the outset, which has advantageous handling properties.
- a reduction stage can be provided via the planetary gear, which has a coaxial axis of rotation to a drive motor shaft.
- This reduction stage is designed so that a drive train is in line with the drive motor shaft. This avoids a transverse offset in a housing of the polishing machine and the corresponding housing can be realized with a minimized height in the direction of the axis of rotation of the polishing tool shaft.
- the handling of the polishing machine which in particular has handle areas on the housing, is facilitated by a correspondingly flat housing; Due to the corresponding compact structure, a polishing process can be carried out in an optimized manner by a user.
- a rotation axis of the drive motor shaft and a main axis of the planetary gear are coaxial with each other.
- the main axis of the planetary gear is, for example, a corresponding axis of a sun gear of the planetary gear, the planetary gears of the planetary gear being orbital to the main axis.
- a locking device for locking a rotatability of the polishing tool shaft acts on the planetary gear carrier.
- a locking device is required in order to fix the polishing tool shaft in terms of its ability to rotate for a tool change.
- the locking device acts directly on the planetary gear carrier.
- an actuating element of the locking device which is actuated by a user, can be arranged outside of the gripping areas of the polishing machine. The risk of accidental locking, for example during operation of the polishing machine, is greatly reduced.
- a planetary gear carrier can be designed for locking in a simple manner, since a housing must already be present to hold the planetary gears anyway. Furthermore, in the case of forced locking when the machine is coasting down, the rotational speed and the rotational energy resulting therefrom are reduced, in particular on a rotor of the motor. Due to the resulting reduced torque, the force load on a locking pin is reduced.
- a sun gear of the planetary gear is non-rotatably connected to the drive motor shaft.
- the drive torque of the drive motor can be coupled into the planetary gear via the sun gear of the planetary gear.
- a ring gear of the planetary gear is arranged in a housing in a rotationally fixed manner. This allows a planetary gear carrier (web) rotate. The corresponding drive torque can be coupled into a further reduction stage.
- the ring gear has an external thread and is fixed in the housing with the external thread.
- the planetary gear can be assembled in a simple manner during manufacture of the polishing machine.
- the ring gear is arranged in a conical seat in the housing.
- a screw fixation of the ring gear can make an exact coaxial positioning to an axis of rotation of the drive motor shaft more difficult.
- a conical seat By providing a conical seat, a coaxial alignment with a high degree of accuracy can be implemented in a simple manner.
- the planetary gear carrier of the planetary gear on which a plurality of planetary gears is arranged, is rotatably mounted in a housing.
- the drive motor shaft drives the planetary gear carrier in rotation via a sun gear.
- the drive torque of the planetary gear carrier can then in turn be passed on to a further reduction stage of the reduction gear.
- the Planetary gear carrier can fulfill a number of tasks; it serves to attach a gear such as a bevel gear of a further reduction stage. It is used to center a sun gear. It provides a counter-element for storing planetary gears.
- the polishing tool shaft can be locked via the planetary gear carrier.
- drive torque is provided in the planetary gear carrier by a sun gear driven by the drive motor shaft. This allows a reduction stage to be implemented in a simple manner.
- the planetary gear carrier provides the drive torque to a further reduction stage of the reduction gear.
- the planetary gear carrier has a reduced speed with respect to a speed of the drive motor shaft. It has a higher speed than the polishing tool shaft.
- polishing tool shaft is then directly coupled to the further gear stage. This allows a two-stage reduction gear to be formed in a simple manner.
- the further reduction stage is an angular gear.
- bevel gears are bevel gears or crown gears. This makes it possible to realize a polishing machine which has a longitudinal extent in an axis which is in particular coaxial to an axis of rotation of the drive motor shaft, with an axis of rotation of a polishing tool lying transversely and in particular perpendicularly to this axis.
- a gear of a further reduction stage of the reduction gear is connected to the planetary gear carrier in a rotationally fixed manner.
- the gear is, for example, a bevel gear (of a bevel gear) or a face gear (of a face gear).
- an axis of rotation of the planetary gear carrier and an axis of rotation of the drive motor shaft are coaxial. Due to a linear arrangement of the corresponding reduction stage and the drive motor shaft, this results in a housing design with a minimized height in the direction of the axis of rotation of the polishing tool shaft.
- the locking device has an engagement element, which is formed, for example, like a pin, which in a corresponding Recess of the planetary gear carrier can be immersed in order to block its rotation. This allows the polishing tool shaft to be rotationally fixed in a simple manner by rotationally fixing the planetary gear carrier.
- a recess device with a recess is designed asymmetrically in relation to a direction of rotation of the planetary gear carrier.
- This asymmetrical design can be achieved in particular via the walls delimiting the recess.
- a running side of the recess has an elevation and, optionally, a running side of the recess also has a material reduction. This achieves a kind of engagement delay. Dipping of the engagement element into a recess should be prevented during operation of the polishing machine.
- a user can push the engagement member toward the planetary gear carrier and cause dipping by manually rotating the burnishing tool shaft.
- the manual rotation is slow.
- the increase in distance to the recess prevents immersion when the engagement element is in contact with the elevation, since immersion generally cannot occur during the brief period of rotation of the recess via the engagement element.
- an actuating element of the locking device is arranged in an area of the housing which surrounds the planet gear carrier.
- the actuating element of the locking device is an actuating device for a user.
- the actuating element is designed in the manner of a push button. If it is arranged in the area of the housing which surrounds the planetary gear carrier, then the engagement element can easily be immersed in a corresponding recess by means of a linear movement of the corresponding handle element, this linear movement being activated by acting on the actuating element.
- the operating element is arranged outside of a grip area for holding the polishing machine by a user during the polishing process. This minimizes the risk of unintentional actuation during a polishing process. This can be implemented in a simple manner by the action of the locking device on the planetary gear carrier.
- a sun gear of the planetary gear has a centering collar on one end. This allows the polishing machine to be manufactured in a simple manner.
- the sun gear can be brought into effective contact with a plurality of planetary gears of the planetary gear in a simple manner via the centering collar.
- a planet gear carrier then has a recess for the centering collar.
- the centering collar is positioned in this recess and advantageously does not touch the planet gear carrier when it rotates.
- planetary gears of the planetary gear are each arranged on a sleeve, and in particular a needle sleeve, which is seated on a planetary gear carrier. This allows the planetary gear to be manufactured in a simple manner.
- the sleeve is fixed to the planet gear carrier in each case via a pin element.
- the planetary gear can be manufactured in a simple manner.
- the drive motor advantageously provides a speed in the range between 20,000 rpm and 40,000 rpm.
- the drive motor shaft is driven at this speed.
- the reduction gear ensures a corresponding reduction.
- the planetary gear provides an output speed in the range between 5,000 rpm and 10,000 rpm.
- the high speed provided by the drive motor shaft is reduced to a medium speed.
- the polishing tool shaft has a speed in the range between 400 rpm and 3000 rpm and in particular in the range between 600 rpm and 2200 rpm. Preferably the speed is adjustable to suit a given workpiece. This results in optimized polishing results.
- a further reduction stage is provided between the planetary gear and the polishing tool shaft, which provides for the reduction from a medium speed to the lower speeds mentioned.
- the drive motor is an electric motor. This makes it easy to realize a compact, hand-held polishing machine.
- a housing area in which the drive motor is arranged provides a gripping area for a user of the polishing machine via its outer surface. A user can then grasp the polishing machine in this housing area. With the other hand he can hold the polishing machine in a head area.
- the housing 12 comprises a first housing shell 14.
- a second housing shell 16 is fixed to the first housing shell 14.
- the second housing shell 16 (and optionally the first housing shell 14) is formed in two parts, for example, with a first part 18 and a second part 20.
- housing 12 has two housing shells and an enclosed area.
- the polishing machine 10 has three sections: a head 22, a middle section 24 which follows the head 22, and a tail section 26, with the middle section 24 lying between the head 22 and the tail section 26.
- the first part 18 of the second housing shell 16 closes the housing 12 at the head 22 and the second part 20 of the second housing shell 16 closes the housing 12 at the central area 24 and the end area 26.
- a polishing tool shaft 28 protrudes from the housing 12 and can be rotated about an axis of rotation 32 in a direction of rotation 30 .
- a polishing tool and in particular a polishing disk can be fixed to the polishing tool shaft 28 by means of suitable fixing means.
- the polishing tool shaft 28 projects beyond an underside 34 of the housing 12 .
- This underside 34 is formed by a corresponding shell part 36a of the first housing shell 14 and by corresponding shell parts 36b, 36c of the second housing shell 16.
- the axis of rotation 32 of the polishing tool shaft 28 lies on a central plane 38 of the polishing machine. At this center plane 38, the first housing shell 14 and the second housing shell 16 meet at least approximately. (The first housing shell 14 and/or the second housing shell 16 can have a fold or a fold recess for the tight closure of the housing 12.)
- a drive motor 40 which is an electric motor ( Figures 2 to 4 ).
- a switch 42 for activating/deactivating the drive motor 40 is arranged on the end region 26 .
- a corresponding circuit arrangement is positioned in the end region 26 in the housing 12 .
- a cable 44 leads to the connection of the polishing machine 10 to an electrical supply device and in particular to a power supply system in the end region 26.
- a reduction gear 46 is arranged, which is designed in two stages with a first reduction stage 48, which includes a planetary gear 50, and with a second reduction stage 52, which is serially connected to the first reduction stage 48 and includes an angular gear 54 ( figures 2 , 3 ).
- the polishing tool shaft 28 is coupled to the second gear reduction stage 52 .
- the polishing machine 10 includes a drive motor shaft 56 ( figure 4 ), which is rotatable about an axis of rotation 58.
- the axis of rotation 58 is transverse and in particular perpendicular to the axis of rotation 32 of the polishing tool shaft 28.
- the drive motor shaft 56 is part of the drive motor 40 or is coupled directly to the drive motor 40.
- the drive motor shaft 56 is connected via a bearing device 60 ( figure 6 ) stored in the housing 12. It is non-rotatably connected to a rotor (armature) 62 on which a laminated core 64 ( figure 4 ) sits.
- the drive motor 40 also has a stator 65 ( figure 3 ) on.
- the housing 12 is provided with air slots 66a, 66b ( figure 1 ) for air cooling of the drive motor 40, with air slots 66a being arranged on the head 22 and in particular on the underside 34 in the vicinity of the polishing tool shaft 28.
- Air slots 66b are arranged laterally on the housing 12 in the end region 26 . A flow of air sucked in by the rotor 62 can flow through the housing 12 in the area of the drive motor 40 between the air slots 66a and 66b.
- the drive motor shaft 56 has a speed which is on the order of 30,000 rpm.
- the reduction gear 46 slows the speed for the burnishing tool shaft 28 and specifically slows it down to a speed on the order of 2,000 rpm.
- the speed of the drive motor shaft 56 is reduced to a speed lying between the speed of the polishing tool shaft 28 and the drive motor shaft 56 . For example, there is a reduction to a speed of the order of magnitude of 7,000 rpm.
- the second reduction stage 52 starting from this speed, the final reduction to the effective speed of the polishing tool shaft 28 then takes place.
- a sun gear 68 ( Figures 4 to 6 ) of the planetary gear 50 connected. This sun gear 68 ensures that the drive motor shaft 56 is coupled to the planetary gear 50. An axis of rotation of the sun gear 68 corresponds to the axis of rotation of the drive motor shaft 56.
- the sun gear 68 has a centering collar 70 at its front end ( figures 4 , 6 ).
- the sun gear 68 has a diameter D 1 ( figure 6 ) on.
- the sun gear 68 has a diameter D 2 which is smaller than the diameter D 1 .
- This centering collar 70 facilitates assembly of the polishing machine 10 when a planetary gear carrier 72 ( figures 2 , 3 , 7 ) is to be placed on the sun gear 68 with engagement of planetary gears 74.
- the planet gear carrier 72 includes a cage 76 which holds a plurality of planet gears 74 .
- the planetary gears 74 each have an axis 78 which is oriented parallel to a main axis 80 of the planetary gear 50 .
- the main axis 80 is also a central axis of the planetary gear carrier 72 and the "sun center" for the planetary gears 74.
- the cage 76 has side windows 82 corresponding to the number of planet gears 74 .
- a planet gear 74 is partially immersed through the respective window 82 .
- a planet gear 74 has a recess 84 in which a sleeve 86 is positioned.
- the sleeve 86 is in particular pressed into the recess 84 so that the corresponding planet wheel 74 is fixed to the sleeve 86 by being pressed in.
- a pin element 88 which is fixed to the cage 76 is in turn seated on the sleeve 86 .
- the cage 76 has a disk element 90 .
- a ring member 92 Positioned opposite and spaced therefrom is a ring member 92 .
- the pin member 88 of the corresponding planetary gear 74 is fixed to the disk member 90 and to the opposed ring member 92 .
- the planetary gears 74 are seated between the disc member 90 and the ring member 92 with lands 94 connecting the disc member 90 and the ring member 92.
- the respective windows 82 are formed between adjacent webs 94 .
- a spindle extension 96 is formed on the disk element 90 . This spindle extension 76 is used for connection to the second stage 52 of the reduction gear 46.
- the ring element 92 has a penetration area 98 through which the sun gear 68 is immersed.
- the sun gear 68 meshes with the planetary gears 74.
- the planet gear carrier 72 is arranged in the housing 12 such that it can rotate about an axis of rotation 100 .
- the axis of rotation 100 is coaxial with the axis of rotation 58 of the drive motor shaft 56 and thus also coaxial with the main axis 80 of the planetary gear 50.
- the planet gear carrier 72 has a recess 97 ( figure 7 ) for the centering collar 70 of the sun gear 68.
- the centering collar 70 can dip into this recess 97 when the planetary gear carrier 72 is positioned correctly with respect to the sun gear 68 with engagement of the planetary gears 74 on the sun gear 68 .
- the recess 97 is preferably designed so that the sun gear 68 does not touch the planet gear carrier 72 in the area of the centering collar 70.
- a rotary bearing 102 is arranged around the drive motor shaft 56 between the sun gear 68 and the bearing device 60 ( figure 6 ), via which the planetary gear carrier 72 can be supported in this area without impeding the ability to rotate.
- a further rotary bearing 104 is arranged in the housing 12 and is in particular adjacent to the second reduction stage 52 of the reduction gear 46 , via which the planetary gear carrier 72 is rotatably supported in the area of the spindle extension 96 in the housing 12 .
- a ring gear 106 is positioned on the head 22 in a rotationally fixed manner in the housing 12 .
- the ring gear 106 has a toothing 108 which faces the planetary gears 74 of the planetary gear carrier 72 and is adapted to this.
- the toothing of the planetary gears 74 engages in this toothing 108 of the ring gear 106 .
- the rotation of the sun gear 68 by the drive motor shaft 56 causes a rotation of the planetary gear carrier 72 with the spindle extension 96 as a whole about the axis of rotation 100.
- the ring gear 106 which is non-rotatably arranged in the housing 12 and on which the planetary gears 74 act, represents a counter-element of the planetary gear 50.
- the translation of the planetary gear 50 is determined by the ratio of the number of teeth of the toothing 108 of the ring gear 106 to the number of teeth of the sun gear 68.
- the larger this ratio the larger the reduction, i.e. the smaller the speed of the planetary gear carrier 72 and thus of the spindle extension 96 compared to the speed of the drive motor shaft 56.
- the ratio of the speed of the sun gear 68 (and hence the drive motor shaft 56) to the speed of the spindle extension 96 is in the range of 3 to 5.
- a typical ratio for the number of teeth of the teeth 108 to the number of teeth of the sun gear 68 is of the order of 3.
- the ring gear 106 has an external thread 110 with which it is screwed in the housing 12 for non-rotatable fixing to a corresponding mating thread.
- a conical seat 112 is provided in this case in order to obtain an exact alignment of a central axis of the ring gear 106 coaxially to the axis of rotation 100 . Due to the screw fixation of the ring gear 106 in the housing 12 and the provision of the conical seat 112, the ring gear 106 can be fixed in a simple manner during the manufacture of the polishing machine 10 and an exact alignment can be achieved. (If the ring gear 106 is fixed in the housing 12 without a conical seat 112 only with an external thread, the alignment is less precise for manufacturing reasons.)
- Gears of the planetary gear 50 and in particular the planetary gears 74 are preferably made of a plastic material. As a result, a noise reduction can be achieved in comparison with metal gears.
- the sun gear 68 and ring gear 106 may be made of a plastic material or metal.
- a bevel gear 114 of the second reduction stage 52 of the reduction gear 46 sits on the spindle extension 96 and rotates about the axis of rotation 100 at the speed of the planetary gear carrier 72 .
- the planetary gear 50 is coupled to the bevel gear 54 via the bevel gear 114 .
- a ring gear 116 aligned coaxially to the axis of rotation 28 and on which the bevel gear 114 engages, is seated on the polishing tool shaft 28 in a rotationally fixed manner.
- An angular gear 54 is implemented as a bevel gear via the bevel gear 114 and the ring gear 116 .
- the polishing machine 10 has a locking device 118 for non-rotatably fixing the polishing tool shaft 28 for a tool change or for inserting a tool.
- the locking device 118 is designed in such a way that it acts on the planet gear carrier 72 and fixes it in a rotationally fixed manner. This non-rotatable fixing causes a non-rotatable fixing of the polishing tool shaft 28 via the second reduction stage 52 of the reduction gear 46.
- the locking device 118 has an engagement element 120 arranged on the head 22 above the planet gear carrier 74 , for example in the form of a pin element 120 .
- This pin element 120 is supported by a spring 122 .
- the spring 122 tends to push a lower end of the pin member 120 away from the planetary gear carrier 72 in a direction transverse to the axis of rotation 100 .
- an operator In order to move the lower end of the pin element 120 in the corresponding opposite direction, an operator must exert a corresponding force on an actuating element 124 .
- the actuating element 124 is designed in particular as a head which is seated on the pin element 120 and can be actuated from an outside of the housing 12 in the manner of a push button.
- the planet gear carrier 74 has a recess device with recesses 126 at a distance from the ring element 92, into which the pin element 120 can dip. When a pin element 120 has entered a corresponding recess 126, the rotation of the planetary gear carrier 72 and thus also the rotation of the polishing tool shaft 28 is blocked.
- the housing 12 has a rounded transition step 130 on a top surface 128 opposite the underside 34 at the head 22.
- the height of the housing 12 increases in a height direction which is parallel to the direction of the axis of rotation 32.
- the bevel gear 54 is arranged in the area with the lower height. In that area the planetary gear 50 is arranged with the greater height.
- a grip area is formed for a user to hold the polishing machine 10 when polishing, that is, the area 132 is a holding area.
- the housing 12 is rounded at one end 134 .
- the housing 12 also has a handle area 136 in the middle area 24 for a user.
- a hand slip guard 138 can be arranged on the grip area 136 , which is formed, for example, by an elevation on an outer side of the housing 12 .
- Another grip area 139 is formed on the end area 26 .
- a user can grasp the grip portion 139 with one hand and grasp the portion 132 with the other hand.
- the actuating element 124 is arranged outside of the area 132 and outside of the gripping area 139 . This reduces the risk of unintentional actuation.
- the locking device 118 is arranged in particular on the housing 12 in an area which surrounds the planetary gear carrier 72 and in particular its ring element 92 .
- the recess device for immersing the pin element 120 is designed asymmetrically with respect to a direction of rotation of the planetary gear carrier 72.
- the locking device 118 acts on a "medium speed range", namely also the planetary gear carrier 72.
- an elevation 140 is assigned to the recesses 126 on corresponding boundary walls on an incoming side and an elevation 142 is assigned to the opposite outgoing side. If during rotation of the planetary gear carrier 72 may inadvertently the pin member 120 in the direction of the ring member 92 is pressed, a ridge 140 prevents entry into the corresponding recess 126 and thereby an abrupt stop of the planetary gear carrier 72 due to engagement delay.
- Locking is usually effected in such a way that, when the drive motor shaft 56 is stationary, the pin element 120 is moved in the direction of the planetary gear carrier 72 by exerting force on the actuating element 124, and the polishing tool shaft 28 is rotated manually by the user until the pin element 120 can enter a corresponding recess 126. If the rotation of the planetary gear carrier 72 is sufficiently slow, as is achieved, for example, by manual rotation of the polishing tool shaft 28, then immersion and thus blocking of rotation can occur.
- the riser 140 on the leading side causes a sort of time lag for the plunge of the pin member 120.
- the planet carrier 72 has so rotated further so that no immersion can take place since the recess 126 has moved past the pin element 120 .
- the hand-held polishing machine 10 functions as follows: A multi-stage and in particular two-stage reduction gear 46 is provided between the drive motor 40 and the polishing tool shaft 28 . This is coupled to the drive motor shaft 56 on the input side and to the polishing tool shaft 28 on the output side. On the input side, the reduction gear 46 is acted upon by the drive torque and the speed of the drive motor shaft 56 . On the output side (output side), the reduction gear 46 provides the polishing tool shaft 28 and thus a corresponding polishing tool with the drive torque with a Reduction gear 46 set speed, which is less than the speed of the drive motor shaft 56.
- the first reduction stage 48 of the reduction gear 46 which is coupled to the drive motor shaft 56, is a planetary gear 50.
- This makes it possible to rotate the axis of rotation 58 of the drive motor shaft 56 and the axis of rotation 100 of the bevel gear 114 of the second stage 52 of the reduction gear 46 to be arranged in a line, i.e. coaxially.
- This makes it possible to design the housing with a relatively small height in the direction of the axis of rotation 32 of the polishing tool shaft 28 .
- This makes it possible to provide a flat housing 12 when the output speed of the polishing tool shaft 28 is low. This in turn allows the polisher 10 to be held close to the central portion 24 of the housing 12 by hand. This results in easy handling for a user.
- the planetary gear carrier 74 of the planetary gear 50 transmits the drive torque of the drive motor shaft 56 to the bevel gear 114 of the bevel gear 54.
- the planetary gear carrier 72 is therefore used to fasten and drive the bevel gear 114. It is a counter-element for the bearing of the planetary gears 74. It is used to center the sun gear 68.
- the locking device 118 also acts on the planetary gear carrier 72 so that a corresponding actuating element 124 is far removed from a grip area 132 on the head 22 and then accordingly the housing 12 can be formed there with minimized dimensions.
- the bevel gear 54 does not have to be designed in such a way that a locking device can act on it.
- the cage 76 that is present anyway for the planet gear carrier 72 can also be used for the locking device 118 with corresponding recesses 126 .
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Finish Polishing, Edge Sharpening, And Grinding By Specific Grinding Devices (AREA)
- Constituent Portions Of Griding Lathes, Driving, Sensing And Control (AREA)
Description
- Die Erfindung betrifft eine handgehaltene Poliermaschine, umfassend einen Antriebsmotor, eine Antriebsmotorwelle, welche direkt durch den Antriebsmotor angetrieben ist, eine Polierwerkzeugwelle, welche quer zu der Antriebsmotorwelle orientiert ist, und ein Untersetzungsgetriebe, welches an die Antriebsmotorwelle und die Polierwerkzeugwelle gekoppelt ist und welches mindestens zweistufig ist, wobei das Untersetzungsgetriebe als eine Untersetzungsstufe ein Planetengetriebe umfasst.
- Das Untersetzungsgetriebe dient dazu, die durch den Antriebsmotor bereitgestellte Drehzahl der Antriebsmotorwelle auf eine Drehzahl der Polierwerkzeugwelle herabzusetzen, welche geeignet ist für Poliervorgänge. Bei bekannten Poliermaschinen liegt eine solche Drehzahl insbesondere in der Größenordnung von 3.500 U/min.
- Aus der
DE 100 47 312 A1 ist ein steuerbares Planetengetriebe zur Übertragung einer Drehbewegung mit einer zwischen einem Antrieb und einem Abtrieb über ein Hohlrad steuerbaren Drehzahländerung bekannt. - Aus der
DE 102 58 863 A1 ist ein Handwerkzeugmaschinengetriebe, insbesondere für einen Winkelschleifer, mit einer drehbar gelagerten und durch einen Elektromotor antreibbaren Antriebswelle und einer drehbar gelagerten Abtriebswelle zu einem Antrieb eines Werkzeugs bekannt. Es ist ein Planetengetriebe zur Drehmomentübertragung von der Antriebswelle auf die Abtriebswelle vorgesehen. - Aus der
WO 2008/014806 A1 ist ein handgeführtes Elektrowerkzeug bekannt, mit einem Motorgehäuse und einem Getriebegehäuse, wobei im Motorgehäuse ein elektrischer Antriebsmotor mit einer Motorwelle angeordnet ist, im Getriebegehäuse ein Getriebe mit einem Winkelgetriebe und einer Werkzeugspindel angeordnet sind, und wobei die Werkzeugspindel in einem zumindest näherungsweise rechten Winkel zur Motorwelle liegt und von der Motorwelle über das Getriebe angetrieben ist. Das Getriebe weist zusätzlich zum Winkelgetriebe ein Planetengetriebe auf. DieWO 2008/ 014806 A1 bildet die Basis für den Oberbegriff des Anspruchs 1. - Der Erfindung liegt die Aufgabe zugrunde, eine handgehaltene Poliermaschine der eingangs genannten Art bereitzustellen, welche vorteilhafte Handhabungseigenschaften aufweist.
- Diese Aufgabe wird durch eine Poliermaschine mit den Merkmalen des Anspruchs 1 gelöst.
- Über das Planetengetriebe lässt sich eine Untersetzungsstufe bereitstellen, welche eine koaxiale Drehachse zu einer Antriebsmotorwelle aufweist. Diese Untersetzungsstufe ist so ausgebildet, dass ein Antriebsstrang auf einer Linie mit der Antriebsmotorwelle liegt. Dadurch ist ein Querversatz in einem Gehäuse der Poliermaschine vermieden und das entsprechende Gehäuse lässt sich mit einer minimierten Höhe in Richtung der Drehachse der Polierwerkzeugwelle realisieren.
- Durch ein entsprechendes flachgebautes Gehäuse wird die Handhabung der Poliermaschine, welche insbesondere Griffbereiche am Gehäuse aufweist, erleichtert; durch den entsprechenden kompakten Aufbau lässt sich ein Poliervorgang durch einen Anwender optimiert durchführen.
- In einem Planetengetriebe sind innere Kräfte aufgehoben. Dadurch ergibt sich eine minimierte Geräuschentwicklung der Poliermaschine im Betrieb. Weiterhin lässt sich dann das Untersetzungsgetriebe mit hoher Laufruhe und geringem Verschleiß realisieren.
- Eine Drehachse der Antriebsmotorwelle und eine Hauptachse des Planetengetriebes sind koaxial zueinander.
- Die Hauptachse des Planetengetriebes ist beispielsweise eine entsprechende Achse eines Sonnenzahnrads des Planetengetriebes, wobei die Planetenzahnräder des Planetengetriebes orbital zu der Hauptachse sind.
- Eine Arretierungseinrichtung zum Arretieren einer Drehbarkeit der Polierwerkzeugwelle wirkt auf den Planetenzahnradträger. Eine Arretierungseinrichtung wird benötigt, um für einen Werkzeugwechsel die Polierwerkzeugwelle in ihrer Drehbarkeit zu fixieren. Bei der erfindungsgemäßen Lösung wirkt die Arretierungseinrichtung direkt auf den Planetenzahnradträger. Dadurch lässt sich ein Betätigungselement der Arretierungseinrichtung, welches durch einen Anwender betätigt wird, außerhalb von Griffbereichen der Poliermaschine anordnen. Es ist die Gefahr einer unbeabsichtigten Arretierung beispielsweise während des Betriebs der Poliermaschine stark verringert. Weiterhin muss dann keine Arretierungseinrichtung beispielsweise im Bereich eines Winkelgetriebes vorgesehen werden, so dass sich der entsprechende Bereich der Poliermaschine auf einfache Weise ausbilden lässt und dieser sich auch für die Handhabung der Poliermaschine (zum Halten durch einen Anwender) ergonomisch optimiert ausbilden lässt. Ein Planetenzahnradträger lässt sich auf einfache Weise zum Arretieren ausbilden, da zum Halten der Planetenzahnräder sowieso bereits ein Gehäuse vorhanden sein muss. Weiterhin ist bei einem erzwungenen Arretieren beim Auslauf der Maschine die Drehzahl und die daraus resultierende Rotationsenergie insbesondere an einem Rotor des Motors verringert. Durch das resultierende verringerte Drehmoment ist die Kraftbelastung eines Arretierstifts verringert.
- Insbesondere ist ein Sonnenzahnrad des Planetengetriebes mit der Antriebsmotorwelle drehfest verbunden. Über das Sonnenzahnrad des Planetengetriebes lässt sich das Antriebsmoment des Antriebsmotors in das Planetengetriebe einkoppeln.
- Es ist ferner günstig, wenn ein Hohlzahnrad des Planetengetriebes drehfest in einem Gehäuse angeordnet ist. Dadurch lässt sich ein Planetenzahnradträger (Steg) rotieren. Das entsprechende Antriebsmoment lässt sich in eine weitere Untersetzungsstufe einkoppeln.
- Ganz besonders vorteilhaft ist es, wenn das Hohlzahnrad ein Außengewinde aufweist und im Gehäuse mit dem Außengewinde fixiert ist. Dadurch kann bei der Herstellung der Poliermaschine das Planetengetriebe auf einfache Weise montiert werden.
- Es ist dabei ganz besonders vorteilhaft, wenn das Hohlzahnrad in dem Gehäuse in einem Kegelsitz angeordnet ist. Grundsätzlich kann eine Schraubenfixierung des Hohlzahnrads eine exakte koaxiale Positionierung zu einer Drehachse der Antriebsmotorwelle erschweren. Durch das Vorsehen eines Kegelsitzes lässt sich auf einfache Weise eine koaxiale Ausrichtung mit hoher Genauigkeit realisieren.
- Ganz besonders vorteilhaft ist es, wenn der Planetenzahnradträger des Planetengetriebes, an welchem eine Mehrzahl von Planetenzahnrädern angeordnet ist, drehbar in einem Gehäuse gelagert ist. Die Antriebsmotorwelle treibt über ein Sonnenzahnrad den Planetenzahnradträger rotativ an. Das Antriebsmoment des Planetenzahnradträgers lässt sich dann wiederum an eine weitere Untersetzungsstufe des Untersetzungsgetriebes weitergeben. Der Planetenzahnradträger kann dabei eine Mehrzahl von Aufgaben erfüllen; er dient zur Befestigung eines Zahnrads wie beispielsweise eines Kegelzahnrads einer weiteren Untersetzungsstufe. Er dient zur Zentrierung eines Sonnenzahnrads. Er stellt ein Gegenelement zur Lagerung von Planetenzahnrädern bereit. Weiterhin lässt sich bei einer Ausführungsform der erfindungsgemäßen Lösung eine Arretierung der Polierwerkzeugwelle über den Planetenzahnradträger durchführen.
- Insbesondere ist im Planetenzahnradträger ein Antriebsmoment durch ein von der Antriebsmotorwelle angetriebenes Sonnenzahnrad bereitgestellt. Es lässt sich dadurch auf einfache Weise eine Untersetzungsstufe realisieren.
- Weiterhin stellt der Planetenzahnradträger einer weiteren Untersetzungsstufe des Untersetzungsgetriebes das Antriebsmoment bereit. Der Planetenzahnradträger weist eine verringerte Drehzahl bezüglich einer Drehzahl der Antriebsmotorwelle auf. Er weist eine größere Drehzahl als die Polierwerkzeugwelle auf.
- Insbesondere ist dann an die weitere Getriebestufe die Polierwerkzeugwelle direkt gekoppelt. Dadurch lässt sich ein zweistufiges Untersetzungsgetriebe auf einfache Weise ausbilden.
- Insbesondere ist die weitere Untersetzungsstufe ein Winkelgetriebe. Beispiele für Winkelgetriebe sind Kegelradgetriebe oder Kronenradgetriebe. Dadurch lässt sich eine Poliermaschine realisieren, welche eine Längserstreckung in einer Achse aufweist, welche insbesondere koaxial zu einer Drehachse der Antriebsmotorwelle ist, wobei eine Drehachse eines Polierwerkzeugs quer und insbesondere senkrecht zu dieser Achse liegt.
- Insbesondere ist ein Zahnrad einer weiteren Untersetzungsstufe des Untersetzungsgetriebes drehfest mit dem Planetenzahnradträger verbunden. Dadurch lässt sich auf einfache Weise ein Winkelgetriebe mit einer weiteren Untersetzung realisieren. Das Zahnrad ist beispielsweise ein Kegelzahnrad (eines Kegelradgetriebes) oder ein Kronenzahnrad (eines Kronenradgetriebes).
- Günstigerweise sind eine Drehachse des Planetenzahnradträgers und eine Drehachse der Antriebsmotorwelle koaxial. Dadurch ergibt sich aufgrund einer linearen Anordnung der entsprechenden Untersetzungsstufe und der Antriebsmotorwelle eine Gehäuseausbildung mit minimierter Höhe in Richtung der Drehachse der Polierwerkzeugwelle.
- Insbesondere weist die Arretierungseinrichtung ein Eingriffelement auf, welches beispielsweise stiftartig ausgebildet ist, welches in eine entsprechende Ausnehmung des Planetenzahnradträgers eintauchbar ist, um dessen Drehbarkeit zu sperren. Dadurch lässt sich auf einfache Weise eine Drehfixierung der Polierwerkzeugwelle über Drehfixierung des Planetenzahnradträgers erreichen.
- Ganz besonders vorteilhaft ist es, wenn eine Ausnehmungseinrichtung mit einer Ausnehmung bezogen auf eine Drehrichtung des Planetenzahnradträgers asymmetrisch ausgebildet ist. Diese asymmetrische Ausbildung lässt sich insbesondere über die Ausnehmung begrenzende Wände erreichen. Es ist dabei vorteilhafterweise vorgesehen, dass eine auflaufende Seite an der Ausnehmung eine Erhöhung aufweist und fakultativ zusätzlich eine ablaufende Seite der Ausnehmung eine Materialerniedrigung aufweist. Dadurch wird eine Art von Eingriffverzögerung erreicht. Ein Eintauchen des Eingriffelements in eine Ausnehmung soll im Betrieb der Poliermaschine verhindert werden. Wenn die Antriebsmotorwelle nicht im Betrieb ist, dann kann ein Anwender das Eingriffelement in Richtung des Planetenzahnradträgers drücken und durch manuelle Rotation der Polierwerkzeugwelle ein Eintauchen bewirken. Die manuelle Rotation ist dabei langsam. Bei schneller Rotation im Betrieb verhindert die Erhöhung über Abstandserhöhung zu der Ausnehmung, wenn das Eingriffelement an der Erhöhung anliegt, ein Eintauchen, da während der kurzen Zeit des Rotierens der Ausnehmung über das Eingriffelement ein Eintauchen in der Regel nicht erfolgen kann.
- Insbesondere ist ein Betätigungselement der Arretierungseinrichtung in einem Bereich des Gehäuses angeordnet, welcher den Planetenzahnradträger umgibt. Das Betätigungselement der Arretierungseinrichtung ist eine Betätigungseinrichtung für einen Anwender. Insbesondere ist das Betätigungselement in der Art eines Druckknopfes ausgebildet. Wenn es in dem Bereich des Gehäuses angeordnet ist, welcher den Planetenzahnradträger umgibt, dann lässt sich auf einfache Weise durch eine Linearbewegung des entsprechenden Handgriffelements, wobei diese Linearbewegung durch Einwirkung auf das Betätigungselement aktiviert wird, eine Eintauchung des Eingriffelements in eine entsprechende Ausnehmung erreichen.
- Insbesondere ist das Betätigungselement außerhalb eines Griffbereichs zum Halten der Poliermaschine durch einen Anwender beim Poliervorgang angeordnet. Dadurch ist die Gefahr einer unbeabsichtigten Betätigung während eines Poliervorgangs minimiert. Durch die Einwirkung der Arretierungseinrichtung auf den Planetenzahnradträger lässt sich dies auf einfache Weise realisieren.
- Bei einer vorteilhaften Ausführungsform weist ein Sonnenzahnrad des Planetengetriebes an einer Stirnseite einen Zentrierbund auf. Dadurch lässt sich die Fertigung der Poliermaschine auf einfache Weise durchführen. Über den Zentrierbund kann das Sonnenzahnrad auf einfache Weise in Einwirckontakt mit einer Mehrzahl von Planetenzahnrädern des Planetengetriebes gebracht werden.
- Insbesondere weist dann ein Planetenzahnradträger eine Ausnehmung für den Zentrierbund auf. Wenn das Planetengetriebe fertig montiert ist, dann ist der Zentrierbund in dieser Ausnehmung positioniert und berührt dabei vorteilhafterweise bei einer Rotation des Planetenzahnradträgers diesen nicht.
- Bei einer Ausführungsform sind Planetenzahnräder des Planetengetriebes jeweils an einer Hülse und insbesondere Nadelhülse angeordnet, welche an einem Planetenzahnradträger sitzt. Dadurch lässt sich das Planetenzahnrad auf einfache Weise fertigen.
- Insbesondere ist die Hülse jeweils über ein Stiftelement an dem Planetenzahnradträger fixiert. Dadurch lässt sich das Planetengetriebe auf einfache Weise fertigen.
- Aus dem gleichen Grund ist es günstig, wenn eine Hülse an dem zugeordneten Planetenzahnrad durch Presssitz fixiert ist.
- Günstigerweise stellt der Antriebsmotor eine Drehzahl im Bereich zwischen 20.000 U/min und 40.000 U/min bereit. Die Antriebsmotorwelle ist mit dieser Drehzahl angetrieben. Das Untersetzungsgetriebe sorgt für eine entsprechende Untersetzung.
- Es ist ferner vorgesehen, dass das Planetengetriebe eine Ausgangsdrehzahl im Bereich zwischen 5.000 U/min und 10.000 U/min bereitstellt. In dem Planetengetriebe wird die von der Antriebsmotorwelle bereitgestellte hohe Drehzahl auf eine mittlere Drehzahl heruntergesetzt.
- Die Polierwerkzeugwelle weist eine Drehzahl im Bereich zwischen 400 U/min und 3.000 U/min und insbesondere im Bereich zwischen 600 U/min und 2.200 U/min auf. Vorzugsweise ist die Drehzahl zur Anpassung an ein gegebenes Werkstück einstellbar. Dadurch ergeben sich optimierte Polierergebnisse. Es ist eine weitere Untersetzungsstufe zwischen Planetengetriebe und Polierwerkzeugwelle vorgesehen, welche für die Herabsetzung von einer mittleren Drehzahl auf die genannten niedrigeren Drehzahlen bereitstellt.
- Insbesondere ist der Antriebsmotor ein Elektromotor. Dadurch lässt sich eine kompakte handgehaltene Poliermaschine auf einfache Weise realisieren.
- Bei einer Ausführungsform stellt ein Gehäusebereich, in welchem der Antriebsmotor angeordnet ist, über seine Außenfläche einen Griffbereich für einen Anwender der Poliermaschine bereit. Ein Anwender kann dann die Poliermaschine in diesem Gehäusebereich umgreifen. Mit der anderen Hand kann er die Poliermaschine in einem Kopfbereich halten.
- Die nachfolgende Beschreibung bevorzugter Ausführungsformen dient im Zusammenhang mit den Zeichnungen der näheren Erläuterung der Erfindung. Es zeigen:
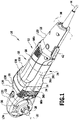
- Figur 1
- Eine perspektivische Darstellung eines Ausführungsbeispiels einer erfindungsgemäßen handgehaltenen Poliermaschine ohne Polierwerkzeug;
- Figur 2
- eine perspektivische Teilschnittansicht der Poliermaschine gemäß
Figur 1 im Bereich eines Kopfes; - Figur 3
- eine weitere perspektivische Teilschnittansicht im Bereich des Kopfes der Poliermaschine gemäß
Figur 1 ; - Figur 4
- eine Teildarstellung eines Motorbereichs der Poliermaschine gemäß
Figur 1 ; - Figur 5
- eine Draufsicht in der Richtung A gemäß
Figur 4 ; - Figur 6
- eine Schnittansicht links der Linie 6-6 gemäß
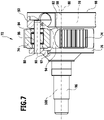
Figur 5 ; - Figur 7
- eine seitliche Ansicht eines Planetenzahnradträgers mit einer Teilschnittdarstellung.
- Ein Ausführungsbeispiel einer erfindungsgemäßen Poliermaschine, welches in einer perspektivischen Darstellung in
Figur 1 gezeigt und dort mit 10 bezeichnet ist, umfasst ein als Ganzes mit 12 bezeichnetes Gehäuse. Bei einem Ausführungsbeispiel umfasst das Gehäuse 12 eine erste Gehäuseschale 14. An der ersten Gehäuseschale 14 ist eine zweite Gehäuseschale 16 fixiert. Die zweite Gehäuseschale 16 (und fakultativ die erste Gehäuseschale 14) ist dabei beispielsweise zweiteilig ausgebildet mit einem ersten Teil 18 und einem zweiten Teil 20. - Bei einer anderen Ausführungsform hat das Gehäuse 12 zwei Gehäuseschalen und einen geschlossenen Bereich.
- Die Poliermaschine 10 weist drei Bereiche auf: Einen Kopf 22, einen Mittelbereich 24, welcher sich an den Kopf 22 anschließt, und einen Endbereich 26, wobei der Mittelbereich 24 zwischen dem Kopf 22 und dem Endbereich 26 liegt.
- Der erste Teil 18 der zweiten Gehäuseschale 16 schließt dabei das Gehäuse 12 an dem Kopf 22 und der zweite Teil 20 der zweiten Gehäuseschale 16 schließt das Gehäuse 12 an dem Mittelbereich 24 und dem Endbereich 26.
- Aus dem Gehäuse 12 ragt eine Polierwerkzeugwelle 28, welche in einer Drehrichtung 30 um eine Drehachse 32 rotierbar ist. An der Polierwerkzeugwelle 28 ist über geeignete Fixierungsmittel ein Polierwerkzeug und insbesondere eine Polierscheibe fixierbar.
- Die Polierwerkzeugwelle 28 ragt über eine Unterseite 34 des Gehäuses 12 heraus. Diese Unterseite 34 ist dabei durch einen entsprechenden Schalenteil 36a der ersten Gehäuseschale 14 und durch entsprechende Schalenteile 36b, 36c der zweiten Gehäuseschale 16 gebildet. Die Drehachse 32 der Polierwerkzeugwelle 28 liegt dabei auf einer Mittelebene 38 der Poliermaschine. An dieser Mittelebene 38 stoßen die erste Gehäuseschale 14 und die zweite Gehäuseschale 16 mindestens näherungsweise aufeinander. (Die erste Gehäuseschale 14 und/oder die zweite Gehäuseschale 16 können dabei einen Falz beziehungsweise eine Falzausnehmung haben zum dichten Abschluss des Gehäuses 12.)
- In dem Mittelbereich 24 der Poliermaschine 10 ist in dem Gehäuse 12 ein Antriebsmotor 40 angeordnet, welcher ein Elektromotor ist (
Figuren 2 bis 4 ). - An dem Endbereich 26 ist ein Schalter 42 zur Aktivierung/Deaktivierung des Antriebsmotors 40 angeordnet. In dem Gehäuse 12 ist in dem Endbereich 26 eine entsprechende Schaltungsanordnung positioniert. Ferner führt ein Kabel 44 zum Anschluss der Poliermaschine 10 an eine elektrische Versorgungseinrichtung und insbesondere an ein Stromnetz in den Endbereich 26.
- In dem Kopf 22 ist ein Untersetzungsgetriebe 46 angeordnet, welches zweistufig ausgebildet ist mit einer ersten Untersetzungsstufe 48, welche ein Planetengetriebe 50 umfasst, und mit einer zweiten Untersetzungsstufe 52, welche seriell an die erste Untersetzungsstufe 48 angeschlossen ist und ein Winkelgetriebe 54 umfasst (
Figuren 2 ,3 ). Die Polierwerkzeugwelle 28 ist an die zweite Untersetzungsstufe 52 angekoppelt. - Die Poliermaschine 10 umfasst eine Antriebsmotorwelle 56 (
Figur 4 ), welche um eine Drehachse 58 rotierbar ist. Die Drehachse 58 liegt dabei quer und insbesondere senkrecht zu der Drehachse 32 der Polierwerkzeugwelle 28. Die Antriebsmotorwelle 56 ist Teil des Antriebsmotors 40 beziehungsweise direkt an den Antriebsmotor 40 gekoppelt. Die Antriebsmotorwelle 56 ist über eine Lagereinrichtung 60 (Figur 6 ) in dem Gehäuse 12 gelagert. Sie ist drehfest mit einem Rotor (Anker) 62 verbunden, an welchem ein Blechpaket 64 (Figur 4 ) sitzt. Der Antriebsmotor 40 weist ferner einen Stator 65 (Figur 3 ) auf. - Das Gehäuse 12 ist mit Luftschlitzen 66a, 66b (
Figur 1 ) zur Luftkühlung des Antriebsmotors 40 versehen, wobei Luftschlitze 66a am Kopf 22 angeordnet sind und insbesondere an der Unterseite 34 in der Nähe der Polierwerkzeugwelle 28 angeordnet sind. Luftschlitze 66b sind lateral an dem Gehäuse 12 in dem Endbereich 26 angeordnet. Eine Luftströmung kann angesaugt durch den Rotor 62 durch das Gehäuse 12 im Bereich des Antriebsmotors 40 zwischen den Luftschlitzen 66a und 66b durchströmen. - Die Antriebsmotorwelle 56 weist eine Drehzahl auf, welche in der Größenordnung von 30.000 U/min liegt. Das Untersetzungsgetriebe 46 setzt die Drehzahl für die Polierwerkzeugwelle 28 herab und setzt diese insbesondere auf eine Drehzahl in der Größenordnung von 2.000 U/min herab. In der ersten Untersetzungsstufe 48 des Untersetzungsgetriebe 46 wird dabei die Drehzahl der Antriebsmotorwelle 56 auf eine zwischen der Drehzahl der Polierwerkzeugwelle 28 und der Antriebsmotorwelle 56 liegenden Drehzahl herabgesetzt. Beispielsweise erfolgt eine Herabsetzung auf eine Drehzahl in der Größenordnung von 7.000 U/min. In der zweiten Untersetzungsstufe 52 erfolgt dann von dieser Drehzahl ausgehend die endgültige Herabsetzung auf die effektive Drehzahl der Polierwerkzeugwelle 28.
- Mit der Antriebsmotorwelle 56 ist drehfest ein Sonnenzahnrad 68 (
Figuren 4 bis 6 ) des Planetengetriebes 50 verbunden. Dieses Sonnenzahnrad 68 sorgt für die Ankopplung der Antriebsmotorwelle 56 an das Planetengetriebe 50. Eine Drehachse des Sonnenzahnrads 68 entspricht der Drehachse der Antriebsmotorwelle 56. - Das Sonnenzahnrad 68 weist an seinem vorderen Ende einen Zentrierbund 70 auf (
Figuren 4 ,6 ). Das Sonnenzahnrad 68 weist quer zur Drehachse 58 einen Durchmesser D1 (Figur 6 ) auf. Im Bereich des Zentrierbunds 70 weist das Sonnenzahnrad 68 einen Durchmesser D2 auf, welcher kleiner ist als der Durchmesser D1. Dieser Zentrierbund 70 erleichtert die Montage der Poliermaschine 10, wenn ein Planetenzahnradträger 72 (Figuren 2 ,3 ,7 ) auf das Sonnenzahnrad 68 mit Eingriff von Planetenzahnrädern 74 aufgesetzt werden soll. - Der Planetenzahnradträger 72 weist einen Käfig 76 auf, welcher eine Mehrzahl von Planetenzahnrädern 74 hält. Es sind insbesondere mindestens drei Planetenzahnräder 74 vorgesehen, welche beabstandet angeordnet sind. Die Planetenzahnräder 74 weisen jeweils eine Achse 78 auf, welche parallel zu einer Hauptachse 80 des Planetengetriebes 50 orientiert ist. Die Hauptachse 80 ist auch eine zentrale Achse des Planetenzahnradträgers 72 und das "Sonnenzentrum" für die Planetenzahnräder 74. Wenn der Planetenzahnradträger 72 an die Antriebsmotorwelle 56 gekoppelt ist, dann sind die Drehachse 58 und die Hauptachse 80 koaxial.
- Der Käfig 76 weist seitliche Fenster 82 entsprechend der Anzahl der Planetenzahnräder 74 auf. Durch das jeweilige Fenster 82 ist ein Planetenzahnrad 74 teilweise durchgetaucht.
- Ein Planetenzahnrad 74 weist eine Ausnehmung 84 auf, in welcher eine Hülse 86 positioniert ist. Die Hülse 86 ist insbesondere in die Ausnehmung 84 eingepresst, so dass das entsprechende Planetenrad 74 eingepresst an der Hülse 86 fixiert ist. An der Hülse 86 wiederum sitzt ein Stiftelement 88, welches an dem Käfig 76 fixiert ist. Der Käfig 76 weist dazu ein Scheibenelement 90 auf. Diesem gegenüberliegend und beabstandet zu diesem ist ein Ringelement 92 positioniert. Das Stiftelement 88 des entsprechenden Planetenzahnrads 74 ist an dem Scheibenelement 90 und an dem gegenüberliegenden Ringelement 92 fixiert. Die Planetenzahnräder 74 sitzen zwischen dem Scheibenelement 90 und dem Ringelement 92, wobei Stege 94 das Scheibenelement 90 und das Ringelelement 92 verbinden. Zwischen benachbarten Stegen 94 sind die jeweiligen Fenster 82 gebildet.
- An dem Scheibenelement 90 ist ein Spindelfortsatz 96 gebildet. Dieser Spindelfortsatz 76 dient zum Anschluss an die zweite Stufe 52 des Untersetzungsgetriebes 46.
- Das Ringelement 92 weist einen Durchtauchbereich 98 auf, durch welchen das Sonnenzahnrad 68 durchgetaucht ist.
- Das Sonnenzahnrad 68 steht in Eingriff mit den Planetenzahnrädern 74.
- Der Planetenzahnradträger 72 ist um eine Drehachse 100 drehbar in dem Gehäuse 12 angeordnet. Die Drehachse 100 ist koaxial zu der Drehachse 58 der Antriebsmotorwelle 56 und damit auch koaxial zur Hauptachse 80 des Planetengetriebes 50.
- Der Planetenzahnradträger 72 weist an dem Scheibenelement 90 eine Ausnehmung 97 (
Figur 7 ) für den Zentrierbund 70 des Sonnenzahnrads 68 auf. In diese Ausnehmung 97 kann der Zentrierbund 70 eintauchen, wenn der Planetenzahnradträger 72 korrekt bezüglich des Sonnenzahnrads 68 mit Eingriff der Planetenzahnräder 74 an dem Sonnenzahnrad 68 positioniert ist. Die Ausnehmung 97 ist dabei bevorzugterweise so ausgestaltet, dass das Sonnenzahnrad 68 im Bereich des Zentrierbunds 70 den Planetenzahnradträger 72 nicht berührt. - Um die Antriebsmotorwelle 56 ist zwischen dem Sonnenzahnrad 68 und der Lagereinrichtung 60 ein Drehlager 102 angeordnet (
Figur 6 ), über welches sich der Planetenzahnradträger 72 in diesem Bereich ohne Behinderung der Drehbarkeit abstützen kann. - In dem Gehäuse 12 ist ein weiteres Drehlager 104 angeordnet, welches insbesondere der zweiten Untersetzungsstufe 52 des Untersetzungsgetriebes 46 benachbart ist, über welches der Planetenzahnradträger 72 im Bereich des Spindelfortsatzes 96 in dem Gehäuse 12 drehbar abgestützt ist.
- In dem Gehäuse 12 ist am Kopf 22 drehfest ein Hohlzahnrad 106 positioniert. Das Hohlzahnrad 106 weist eine den Planetenzahnrädern 74 des Planetenzahnradträgers 72 zugewandte, an diese angepasste Verzahnung 108 auf. Die Verzahnung der Planetenzahnräder 74 greift in diese Verzahnung 108 des Hohlzahnrads 106 ein. Die Rotation des Sonnenzahnrads 68 durch die Antriebsmotorwelle 56 bewirkt eine Rotation des Planetenzahnradträgers 72 mit dem Spindelfortsatz 96 als Ganzes um die Drehachse 100. Das drehfest in Gehäuse 12 angeordnete Hohlzahnrad 106, an welchem die Planetenzahnräder 74 angreifen, stellt ein Gegenelement des Planetengetriebes 50 dar. Die Übersetzung des Planetengetriebes 50 ist bestimmt durch das Verhältnis der Anzahl der Zähne der Verzahnung 108 des Hohlzahnrads 106 zu der Anzahl der Zähne des Sonnenzahnrads 68. Je größer dieses Verhältnis ist, desto größer ist die Untersetzung, das heißt desto kleiner ist die Drehzahl des Planetenzahnradträgers 72 und damit des Spindelfortsatzes 96 im Vergleich zu der Drehzahl der Antriebsmotorwelle 56.
- Vorzugsweise liegt das Verhältnis der Drehzahl des Sonnenzahnrads 68 (und damit der Antriebsmotorwelle 56) zu der Drehzahl des Spindelfortsatzes 96 im Bereich zwischen 3 und 5. Ein typisches Verhältnis für die Anzahl der Zähne der Verzahnung 108 zu der Anzahl der Zähne des Sonnenzahnrads 68 liegt in der Größenordnung von 3.
- Das Hohlzahnrad 106 weist ein Außengewinde 110 auf, mit welchem es in dem Gehäuse 12 zur drehfesten Fixierung an einem entsprechenden Gegengewinde verschraubt ist. Es ist dabei ein Kegelsitz 112 vorgesehen, um eine exakte Ausrichtung einer zentralen Achse des Hohlzahnrads 106 koaxial zu der Drehachse 100 zu erhalten. Durch die Schraubenfixierung des Hohlzahnrads 106 in dem Gehäuse 12 und das Vorsehen des Kegelsitzes 112 lässt sich bei der Herstellung der Poliermaschine 10 das Hohlzahnrad 106 auf einfache Weise fixieren und es lässt sich eine exakte Ausrichtung erreichen. (Wenn das Hohlzahnrad 106 ohne Kegelsitz 112 nur mit einem Außengewinde in dem Gehäuse 12 fixiert ist, ist fertigungsbedingt die Ausrichtung weniger genau.)
- Zahnräder des Planetengetriebes 50 und insbesondere die Planetenzahnräder 74 sind vorzugsweise aus einem Kunststoffmaterial hergestellt. Dadurch lässt sich eine Geräuschreduzierung im Vergleich mit metallischen Zahnrädern erreichen. Das Sonnenzahnrad 68 und Hohlzahnrad 106 können aus einem Kunststoffmaterial oder aus Metall hergestellt sein.
- An dem Spindelfortsatz 96 sitzt ein Kegelzahnrad 114 der zweiten Untersetzungsstufe 52 des Untersetzungsgetriebes 46, welches um die Drehachse 100 mit der Drehzahl des Planetenzahnradträgers 72 rotiert. Über das Kegelzahnrad 114 ist das Planetengetriebe 50 an das Winkelgetriebe 54 angekoppelt.
- An der Polierwerkzeugwelle 28 sitzt drehfest koaxial zu der Drehachse 28 ausgerichtet ein Tellerzahnrad 116, an welchem das Kegelzahnrad 114 angreift. Über das Kegelzahnrad 114 und das Tellerzahnrad 116 ist ein Winkelgetriebe 54 als Kegelgetriebe realisiert. Es erfolgt eine weitere Untersetzung bestimmt durch das Verhältnis der Anzahl der Zahnräder des Kegelzahnrads 114 zu dem Tellerzahnrad 116, wobei weiterhin eine Umlenkung des Antriebsdrehmoments in einer Querrichtung und insbesondere um 90° erfolgt.
- Die Poliermaschine 10 weist eine Arretierungseinrichtung 118 zur drehfesten Fixierung der Polierwerkzeugwelle 28 für einen Werkzeugwechsel beziehungsweise für das Einsetzen eines Werkzeugs auf. Die Arretierungseinrichtung 118 ist dabei so ausgebildet, dass sie auf den Planetenzahnradträger 72 wirkt und diesen drehfest fixiert. Diese drehfeste Fixierung bewirkt vermittelt über die zweite Untersetzungsstufe 52 des Untersetzungsgetriebes 46 eine drehfeste Fixierung der Polierwerkzeugwelle 28.
- Die Arretierungseinrichtung 118 weist ein an dem Kopf 22 oberhalb des Planetenzahnradträgers 74 angeordnetes Eingriffelement 120 beispielsweise in Form eines Stiftelements 120 auf. Dieses Stiftelement 120 ist über eine Feder 122 abgestützt. Die Feder 122 ist bestrebt, ein unteres Ende des Stiftelements 120 von dem Planetenzahnradträger 72 in einer Richtung quer zur Drehachse 100 wegzudrücken. Um das untere Ende des Stiftelements 120 in der entsprechenden Gegenrichtung zu bewegen, muss ein Bediener eine entsprechende Kraft auf ein Betätigungselement 124 ausüben. Das Betätigungselement 124 ist insbesondere als Kopf ausgebildet, welcher an dem Stiftelement 120 sitzt und von einer Außenseite des Gehäuses 12 her betätigbar ist in der Art eines Druckknopfes.
- Der Planetenzahnradträger 74 weist an dem Ringelement 92 beabstandet eine Ausnehmungseinrichtung mit Ausnehmungen 126 auf, in welche das Stiftelement 120 eintauchen kann. Wenn ein Stiftelement 120 in eine entsprechende Ausnehmung 126 eingetaucht ist, dann ist die Drehbarkeit des Planetenzahnradträgers 72 und damit auch die Drehbarkeit der Polierwerkzeugwelle 28 gesperrt.
- Das Gehäuse 12 hat an einer der Unterseite 34 gegenüberliegenden Oberseite 128 am Kopf 22 eine abgerundete Übergangs-Stufe 130. An der Übergangs-Stufe 130 erhöht sich die Höhe des Gehäuses 12 in einer Höhenrichtung, welche parallel zur Richtung der Drehachse 32 ist. In dem Bereich mit der geringeren Höhe ist das Winkelgetriebe 54 angeordnet. In dem Bereich mit der größeren Höhe ist das Planetengetriebe 50 angeordnet. In dem Bereich 132 mit geringerer Höhe ist ein Griffbereich für einen Anwender gebildet, über welchen er die Poliermaschine 10 beim Polieren halten kann, das heißt der Bereich 132 ist ein Haltebereich. Dazu ist insbesondere das Gehäuse 12 an einem Ende 134 abgerundet.
- Das Gehäuse 12 weist ferner in dem Mittelbereich 24 einen Griffbereich 136 für einen Anwender auf. An dem Griffbereich 136 kann eine Handabrutschsicherung 138 angeordnet sein, welche beispielsweise durch eine Erhöhung an einer Außenseite des Gehäuses 12 gebildet ist. Ein weiterer Griffbereich 139 ist an dem Endbereich 26 gebildet.
- Ein Anwender kann den Griffbereich 139 mit einer Hand fassen und mit der anderen Hand den Bereich 132 fassen.
- Das Betätigungselement 124 ist außerhalb des Bereichs 132 und außerhalb des Griffbereichs 139 angeordnet. Dadurch ist die Gefahr einer unbeabsichtigten Betätigung verringert.
- Die Arretierungseinrichtung 118 ist dabei insbesondere an dem Gehäuse 12 an einem Bereich angeordnet, welcher den Planetenzahnradträger 72 und insbesondere dessen Ringelement 92 umgibt.
- Die Ausnehmungseinrichtung zum Eintauchen des Stiftelements 120 ist asymmetrisch ausgestaltet bezüglich einer Drehrichtung des Planetenzahnradträgers 72. Die Arretierungseinrichtung 118 wirkt auf einen "Mitteldrehzahlbereich", nämlich auch den Planetenzahnradträger 72. Um bei sich mit Arbeits-Geschwindigkeit drehendem Planetenzahnradträger 72 einen Eingriff des Stiftelements 120 zu verhindern, ist den Ausnehmungen 126 an entsprechenden Begrenzungswänden an einer auflaufenden Seite jeweils eine Erhöhung 140 zugeordnet und an der gegenüberliegenden ablaufenden Seite eine Erniedrigung 142 zugeordnet. Wenn während Drehung des Planetenzahnradträgers 72 eventuell unbeabsichtigt das Stiftelement 120 in Richtung des Ringelements 92 gedrückt wird, dann verhindert eine Erhöhung 140 ein Eindringen in die entsprechende Ausnehmung 126 und dadurch einen abrupten Stopp des Planetenzahnradträgers 72 aufgrund einer Eingriffverzögerung.
- Üblicherweise erfolgt die Arretierung derart, dass bei stillstehender Antriebsmotorwelle 56 das Stiftelement 120 durch Kraftausüben auf das Betätigungselement 124 in Richtung des Planetenzahnradträgers 72 bewegt wird und die Polierwerkzeugwelle 28 durch den Anwender manuell gedreht wird, bis das Stiftelement 120 in eine entsprechende Ausnehmung 126 eintauchen kann. Wenn die Drehung des Planetenzahnradträgers 72 entsprechend langsam ist, wie es beispielsweise durch manuelle Drehung der Polierwerkzeugwelle 28 erreicht wird, dann kann ein Eintauchen und damit eine Sperrung der Drehbarkeit erfolgen.
- Wenn jedoch der Planetenzahnradträger 72 rotiert (beispielsweise mit einer Drehzahl in der Größenordnung von 7.000 U/min), dann bewirkt die Erhöhung 140 an der auflaufenden Seite eine Art von Zeitverzögerung für das Eintauchen des Stiftelements 120. Während der Verzögerungszeit hat sich der Planetenzahnradträger 72 so weitergedreht, dass kein Eintauchen erfolgen kann, da die Ausnehmung 126 sich an dem Stiftelement 120 vorbeibewegt hat.
- Die erfindungsgemäße handgehaltene Poliermaschine 10 funktioniert wie folgt:
Zwischen dem Antriebsmotor 40 und der Polierwerkzeugwelle 28 ist ein mehrstufiges und insbesondere zweistufiges Untersetzungsgetriebe 46 vorgesehen. Dieses ist eingangsseitig an die Antriebsmotorwelle 56 gekoppelt und ausgangsseitig an die Polierwerkzeugwelle 28 gekoppelt. Eingangsseitig wird das Untersetzungsgetriebe 46 mit dem Antriebsmoment und der Drehzahl der Antriebsmotorwelle 56 beaufschlagt. Abtriebsseitig (ausgangsseitig) stellt das Untersetzungsgetriebe 46 der Polierwerkzeugwelle 28 und damit einem entsprechenden Polierwerkzeug das Antriebsmoment bereit mit einer durch das Untersetzungsgetriebe 46 eingestellten Drehzahl, welche kleiner ist als die Drehzahl der Antriebsmotorwelle 56. - Bei der erfindungsgemäßen Lösung ist die erste Untersetzungsstufe 48 des Untersetzungsgetriebes 46, welches an die Antriebsmotorwelle 56 gekoppelt ist, ein Planetengetriebe 50. Dadurch ist es möglich, die Drehachse 58 der Antriebsmotorwelle 56 und die Drehachse 100 des Kegelzahnrads 114 der zweiten Stufe 52 des Untersetzungsgetriebes 46 auf einer Linie, das heißt koaxial anzuordnen. Dies wiederum ermöglicht es, das Gehäuse mit einer relativ geringen Höhe in Richtung der Drehachse 32 der Polierwerkzeugwelle 28 auszubilden. Dadurch ist es bei geringer Abtriebsdrehzahl der Polierwerkzeugwelle 28 möglich, ein flachgebautes Gehäuse 12 bereitzustellen. Dies wiederum ermöglicht es, die Poliermaschine 10 mit der Hand dicht am Mittelbereich 24 des Gehäuses 12 zu halten. Dadurch ergibt sich eine einfache Handhabbarkeit für einen Anwender.
- In einem Planetengetriebe 50 lassen sich innere Kräfte aufheben. Dadurch ist die Geräuschemission der Poliermaschine 10 verringert.
- Durch die Fixierung des Hohlzahnrads 106 über Verschraubung in dem Gehäuse 12 in einem Kegelsitz lässt sich bei geringem Verschleiß eine hohe Laufruhe erhalten.
- Der Planetenzahnradträger 74 des Planetengetriebes 50 vermittelt das Antriebsmoment der Antriebsmotorwelle 56 an das Kegelzahnrad 114 des Winkelgetriebes 54. Der Planetenzahnradträger 72 dient somit zur Befestigung und zum Antrieb des Kegelzahnrads 114. Er ist ein Gegenelement für die Lagerung der Planetenzahnräder 74. Er dient zur Zentrierung des Sonnenzahnrads 68.
- Bei der erfindungsgemäßen Lösung wirkt ferner die Arretierungseinrichtung 118 auf den Planetenzahnradträger 72, so dass ein entsprechendes Betätigungselement 124 weit entfernt von einem Griffbereich 132 am Kopf 22 ist und dann entsprechend auch das Gehäuse 12 dort mit minimierten Abmessungen ausgebildet werden kann. Ferner muss das Winkelgetriebe 54 dann nicht so ausgestaltet sein, dass eine Arretierungseinrichtung auf es wirken kann. Der sowieso für den Planetenzahnradträger 72 vorhandene Käfig 76 lässt sich mit entsprechenden Ausnehmungen 126 auch für die Arretierungseinrichtung 118 nutzen.
-
- 10
- Poliermaschine
- 12
- Gehäuse
- 14
- Erste Gehäuseschale
- 16
- Zweite Gehäuseschale
- 18
- Erster Teil
- 20
- Zweiter Teil
- 22
- Kopf
- 24
- Mittelbereich
- 26
- Endbereich
- 28
- Polierwerkzeugwelle
- 30
- Drehrichtung
- 32
- Drehachse
- 34
- Unterseite
- 36a
- Schalenteil
- 36b
- Schalenteil
- 36c
- Schalenteil
- 38
- Mittelebene
- 40
- Antriebsmotor
- 42
- Schalter
- 44
- Kabel
- 46
- Untersetzungsgetriebe
- 48
- Erste Untersetzungsstufe
- 50
- Planetengetriebe
- 52
- Zweite Untersetzungsstufe
- 54
- Winkelgetriebe
- 56
- Antriebsmotorwelle
- 58
- Drehachse
- 60
- Lagereinrichtung
- 62
- Rotor
- 64
- Blechpaket
- 65
- Stator
- 66a
- Luftschlitz
- 66b
- Luftschlitz
- 68
- Sonnenzahnrad
- 70
- Zentrierbund
- 72
- Planetenzahnradträger
- 74
- Planetenzahnrad
- 76
- Käfig
- 78
- Achse
- 80
- Hauptachse
- 82
- Fenster
- 84
- Ausnehmung
- 86
- Hülse
- 88
- Stiftelement
- 90
- Scheibenelement
- 92
- Ringelement
- 94
- Steg
- 96
- Spindelfortsatz
- 97
- Ausnehmung
- 98
- Durchtauchbereich
- 100
- Drehachse
- 102
- Drehlager
- 104
- Drehlager
- 106
- Hohlzahnrad
- 108
- Verzahnung
- 110
- Außengewinde
- 112
- Kegelsitz
- 114
- Kegelzahnrad
- 116
- Tellerzahnrad
- 118
- Arretierungseinrichtung
- 120
- Stiftelement
- 122
- Feder
- 124
- Betätigungselement
- 126
- Ausnehmung
- 128
- Oberseite
- 130
- Stufe
- 132
- Griffbereich
- 134
- Ende
- 136
- Griffbereich
- 138
- Handabrutschsicherung
- 139
- Griffbereich
- 140
- Erhöhung
- 142
- Erniedrigung
Claims (15)
- Handgehaltene Poliermaschine, umfassend einen Antriebsmotor (40), eine Antriebsmotorwelle (56), welche direkt durch den Antriebsmotor (40) angetrieben ist, eine Polierwerkzeugwelle (28), welche quer zu der Antriebsmotorwelle (56) orientiert ist, und ein Untersetzungsgetriebe (46), welches an die Antriebsmotorwelle (56) und die Polierwerkzeugwelle (28) gekoppelt ist und welches mindestens zweistufig ist, wobei das Untersetzungsgetriebe (46) als eine Untersetzungsstufe (48) ein Planetengetriebe (50) umfasst, wobei eine Drehachse (58) der Antriebsmotorwelle (56) und eine Hauptachse (80) des Planetengetriebes (50) koaxial sind und dadurch gekennzeichnet, dass eine Arretierungseinrichtung (118) zum Arretieren einer Drehbarkeit der Polierwerkzeugwelle (28) direkt auf den Planetenzahnradträger (72) wirkt.
- Handgehaltene Poliermaschine nach Anspruch 1, dadurch gekennzeichnet, dass ein Sonnenzahnrad (68) des Planetengetriebes (50) mit der Antriebsmotorwelle (56) drehfest verbunden ist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass ein Hohlzahnrad (106) des Planetengetriebes (50) drehfest in einem Gehäuse (12) angeordnet ist, und insbesondere, dass das Hohlzahnrad (106) ein Außengewinde (110) aufweist und in dem Gehäuse (12) mit dem Außengewinde (110) fixiert ist, und insbesondere, dass das Hohlzahnrad (106) in dem Gehäuse (12) in einem Kegelsitz (112) angeordnet ist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass der Planetenzahnradträger (72) des Planetengetriebes (50), an welchem eine Mehrzahl von Planentenzahnrädern (74) angeordnet sind, drehbar in einem Gehäuse (12) gelagert ist, und insbesondere, dass dem Planetenzahnradträger (72) ein Antriebsmoment durch ein von der Antriebsmotorwelle (56) angetriebenes Sonnenzahnrad (68) bereitgestellt ist, und insbesondere, dass der Planentenzahnradträger (74) einer weiteren Untersetzungsstufe (52) des Untersetzungsgetriebes (46) das Antriebsmoment bereitstellt, und insbesondere, dass an die weitere Untersetzungsstufe (52) die Polierwerkzeugwelle (28) direkt gekoppelt ist.
- Handgehaltene Poliermaschine nach Anspruch 4, dadurch gekennzeichnet, dass die weitere Untersetzungsstufe (52) ein Winkelgetriebe (54) umfasst.
- Handgehaltene Poliermaschine nach Anspruch 4 oder 5, dadurch gekennzeichnet, dass ein Zahnrad (114) einer weiteren Untersetzungsstufe (52) des Untersetzungsgetriebes (46) drehfest mit dem Planetenzahnradträger (72) verbunden ist.
- Handgehaltene Poliermaschine nach einem der Ansprüche 4 bis 6, dadurch gekennzeichnet, dass eine Drehachse (100) des Planetenzahnradträgers (52) und eine Drehachse (58) der Antriebsmotorwelle (56) koaxial sind.
- Handgehaltene Poliermaschine nach einem der Ansprüche 4 bis 7, dadurch gekennzeichnet, dass die Arretierungseinrichtung (118) ein Eingriffelement (120) aufweist, welches in eine entsprechende Ausnehmung (126) des Planetenzahnradträgers (72) eintauchbar ist, um dessen Drehbarkeit zu sperren, und insbesondere, dass eine Ausnehmungseinrichtung mit einer Ausnehmung (126) bezogen auf eine Drehrichtung des Planetenzahnradträgers (72) asymmetrisch ausgebildet ist, und insbesondere, dass ein Betätigungselement (124) der Arretierungseinrichtung (118) in einem Bereich des Gehäuses (12) angeordnet ist, welcher den Planetenzahnradträger (72) umgibt, und insbesondere, dass das Betätigungselement (124) außerhalb eines Griffbereichs (132) zum Halten der Poliermaschine durch einen Anwender bei einem Poliervorgang angeordnet ist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass ein Sonnenzahnrad (68) des Planetengetriebes (50) an einer Stirnseite einen Zentrierbund (70) aufweist, und insbesondere, dass ein Planetenzahnradträger (72) eine Ausnehmung (97) für den Zentrierbund (70) aufweist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass Planetenzahnräder (74) des Planetengetriebes (50) jeweils an einer Hülse (86) angeordnet sind, welche an einem Planetenzahnradträger (72) sitzt, und insbesondere, dass die Hülse (86) jeweils über ein Stiftelement (88) an dem Planetenzahnradträger (72) fixiert ist, und insbesondere, dass eine Hülse (86) an dem zugeordneten Planetenzahnrad (74) durch Presssitz fixiert ist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass der Antriebsmotor (40) eine Drehzahl im Bereich zwischen 20.000 U/min und 40.000 U/min bereitstellt.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass das Planetengetriebe (50) eine Ausgangsdrehzahl im Bereich zwischen 5.000 U/min und 10.000 U/min bereitstellt.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass die Polierwerkzeugwelle (28) eine Drehzahl im Bereich zwischen 400 U/min und 3.000 U/min und insbesondere im Bereich zwischen 600 U/min und 2.200 U/min aufweist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass der Antriebsmotor (40) ein Elektromotor ist.
- Handgehaltene Poliermaschine nach einem der vorangehenden Ansprüche, dadurch gekennzeichnet, dass ein Gehäusebereich, in welchem der Antriebsmotor (40) angeordnet ist, über seine Außenfläche einen Griffbereich (139) für einen Anwender der Poliermaschine bereitstellt.
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE102010038976A DE102010038976A1 (de) | 2010-08-05 | 2010-08-05 | Handgehaltene Poliermaschine |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP2415558A2 EP2415558A2 (de) | 2012-02-08 |
| EP2415558A3 EP2415558A3 (de) | 2016-07-13 |
| EP2415558B1 true EP2415558B1 (de) | 2022-10-26 |
Family
ID=44583980
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP11172636.0A Active EP2415558B1 (de) | 2010-08-05 | 2011-07-05 | Handgehaltene Poliermaschine |
Country Status (2)
| Country | Link |
|---|---|
| EP (1) | EP2415558B1 (de) |
| DE (1) | DE102010038976A1 (de) |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP3450099A1 (de) * | 2017-08-28 | 2019-03-06 | Siprotool AG | Bodenschleifmaschine zum schleifen und polieren von böden |
| CN114888682B (zh) * | 2022-03-11 | 2025-11-25 | 江苏明文工具科技有限公司 | 一种扁头角磨机 |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| GB1130679A (en) * | 1966-10-11 | 1968-10-16 | Atlas Copco Ab | Improvements in rotary pneumatic nut runners and like tools |
| US6102632A (en) * | 1998-04-23 | 2000-08-15 | Black & Decker Inc. | Two speed right angle drill |
| DE10047312A1 (de) * | 2000-09-25 | 2002-05-08 | Hilti Ag | Steuerbares Planetengetriebe |
| DE10258863A1 (de) * | 2002-12-17 | 2004-07-08 | Robert Bosch Gmbh | Handwerkzeugmaschinengetriebe und Handwerkzeugmaschine |
| US20050279519A1 (en) * | 2004-06-17 | 2005-12-22 | One World Technologies Limited | Right angle impact driver |
| WO2008014806A1 (de) * | 2006-08-02 | 2008-02-07 | A & M Electric Tools Gmbh | Handgeführtes elektrowerkzeug mit planetengetriebe |
| JP2009220202A (ja) * | 2008-03-14 | 2009-10-01 | Techway Industrial Co Ltd | 電気式研磨ガン |
-
2010
- 2010-08-05 DE DE102010038976A patent/DE102010038976A1/de not_active Withdrawn
-
2011
- 2011-07-05 EP EP11172636.0A patent/EP2415558B1/de active Active
Also Published As
| Publication number | Publication date |
|---|---|
| EP2415558A3 (de) | 2016-07-13 |
| EP2415558A2 (de) | 2012-02-08 |
| DE102010038976A1 (de) | 2012-02-09 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP2627483B1 (de) | Handgeführtes elektrowerkzeug mit einer spindellockvorrichtung | |
| DE19940369C2 (de) | Elektrisch antreibbare Zahnbürste | |
| DE10109741A1 (de) | Verbesserter Kupplungsmechanismus zur Verwendung in Rotationswerkzeugen mit Schraub-und Bohrbetrieb | |
| EP3027361A1 (de) | Werkzeugmaschine mit werkzeugaufnahmeeinrichtung | |
| EP0401548A1 (de) | Schraubwerkzeugmaschine | |
| EP0868264B1 (de) | Elektrohandwerkzeugmaschine | |
| DE3636229A1 (de) | Elektrisches handwerkzeug | |
| WO2002062526A1 (de) | Handwerkzeugmaschine zum schliefen, polieren oder dergleichen | |
| DE10016706A1 (de) | Startvorrichtung | |
| DE4218683C2 (de) | Handstückkopf für ein zahnärztliches Handstück, mit einem Gehäuse, in dem ein Behandlungswerkzeug axial längs seiner Mittelachse hin und her verschiebbar gelagert ist | |
| EP3481593B1 (de) | Handwerkzeugmaschinenvorrichtung | |
| DE102012212404B4 (de) | Handwerkzeugmaschinenvorrichtung | |
| DE4101705C2 (de) | Handgeführte Elektrowerkzeugmaschine mit einer Einrichtung zum schnellen Stillsetzen des Werkzeuges | |
| EP3481590B1 (de) | Handwerkzeugmaschinenvorrichtung | |
| DE3247421A1 (de) | Antriebsvorrichtung, insbesondere fuer scheibenwischer von kraftfahrzeugen | |
| EP2415558A2 (de) | Handgehaltene Poliermaschine | |
| EP0995551B1 (de) | Handführbare Werkzeugmaschine, insbesondere Schrauber oder Bohrschrauber | |
| DE102010064363B4 (de) | Handwerkzeugmaschinenspannvorrichtung mit Verdrehsicherung | |
| DE102014216441A1 (de) | Handwerkzeugmaschine | |
| DE19719923C2 (de) | Bohr-, Bohrschraub- oder Schlagbohrmaschine | |
| EP3895846A1 (de) | Trockenbauschrauber | |
| DE4329181A1 (de) | Antriebsvorrichtung für einen zahnärztlichen Werkzeughalter | |
| DE10258863A1 (de) | Handwerkzeugmaschinengetriebe und Handwerkzeugmaschine | |
| DE69705377T2 (de) | Antrieb, insbesondere für eine elektrische Fahrzeugdiebstahlsicherung | |
| EP2655020A1 (de) | Getriebeanordnung für ein elektrowerkzeug und elektrowerkzeug |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| AK | Designated contracting states |
Kind code of ref document: A2 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| AX | Request for extension of the european patent |
Extension state: BA ME |
|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| TPAC | Observations filed by third parties |
Free format text: ORIGINAL CODE: EPIDOSNTIPA |
|
| PUAL | Search report despatched |
Free format text: ORIGINAL CODE: 0009013 |
|
| AK | Designated contracting states |
Kind code of ref document: A3 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| AX | Request for extension of the european patent |
Extension state: BA ME |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: B24B 23/02 20060101AFI20160608BHEP Ipc: B24B 47/00 20060101ALI20160608BHEP Ipc: B25F 5/00 20060101ALI20160608BHEP Ipc: B24B 47/12 20060101ALI20160608BHEP |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20170110 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: EXAMINATION IS IN PROGRESS |
|
| 17Q | First examination report despatched |
Effective date: 20191127 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20220519 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 502011017385 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: REF Ref document number: 1526717 Country of ref document: AT Kind code of ref document: T Effective date: 20221115 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: GERMAN |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: FP |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20230227 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20230126 Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20230226 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20230127 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 502011017385 Country of ref document: DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 Ref country code: AL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed |
Effective date: 20230727 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20230731 Year of fee payment: 13 Ref country code: GB Payment date: 20230724 Year of fee payment: 13 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20230720 Year of fee payment: 13 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PL |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MM Effective date: 20230801 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20230731 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230801 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: MM4A |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230801 Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230731 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230731 Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230731 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MM01 Ref document number: 1526717 Country of ref document: AT Kind code of ref document: T Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20230705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R119 Ref document number: 502011017385 Country of ref document: DE |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20240705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250201 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20240705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20240705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20110705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20110705 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20221026 |