EP1087200B1 - Flugkörper-Missionseinheit - Google Patents
Flugkörper-Missionseinheit Download PDFInfo
- Publication number
- EP1087200B1 EP1087200B1 EP00116828A EP00116828A EP1087200B1 EP 1087200 B1 EP1087200 B1 EP 1087200B1 EP 00116828 A EP00116828 A EP 00116828A EP 00116828 A EP00116828 A EP 00116828A EP 1087200 B1 EP1087200 B1 EP 1087200B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- missile
- target
- data
- mission unit
- situation
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Lifetime
Links
- 230000009471 action Effects 0.000 claims description 7
- 238000004088 simulation Methods 0.000 claims description 6
- 238000004458 analytical method Methods 0.000 claims description 5
- 238000013528 artificial neural network Methods 0.000 claims description 5
- 238000004364 calculation method Methods 0.000 claims description 5
- 238000001514 detection method Methods 0.000 claims description 5
- 238000011156 evaluation Methods 0.000 claims description 5
- 238000000034 method Methods 0.000 claims description 5
- 230000006870 function Effects 0.000 claims description 3
- 238000010304 firing Methods 0.000 description 5
- 230000006399 behavior Effects 0.000 description 3
- 230000008859 change Effects 0.000 description 2
- 238000004519 manufacturing process Methods 0.000 description 2
- 230000008569 process Effects 0.000 description 2
- 230000001133 acceleration Effects 0.000 description 1
- 230000003044 adaptive effect Effects 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 230000007613 environmental effect Effects 0.000 description 1
- 230000005236 sound signal Effects 0.000 description 1
- 230000004083 survival effect Effects 0.000 description 1
- 230000000007 visual effect Effects 0.000 description 1
Images

Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F41—WEAPONS
- F41G—WEAPON SIGHTS; AIMING
- F41G7/00—Direction control systems for self-propelled missiles
- F41G7/007—Preparatory measures taken before the launching of the guided missiles
Definitions
- the invention relates to a missile mission unit for a missile, to which Sensors for the movement of a target relative to the missile and for the Self-motion of the missile are connected, containing means for detection and Identification and determination of the track of the target, that of data of the sensors resources for situational assessment and analysis from the information about location, type and track of the destination, a first database in which knowledge about potential targets are stored, a second database in which data about the Skills of the missiles are stored, and means of generating plans for Actions and from this are activated to generate decision criteria,
- target-tracking Missiles On a combat aircraft are in use usually several target-tracking Missiles suspended in launchers under the wings.
- the target-tracking Missiles have seekers with sensors that target one or more targets to capture.
- the missile inertial sensors may contain, which on the Respond to movements of the missile in the inertial space. From viewfinder signals of Seekers are generated steering signals that lead the missile to the target.
- From viewfinder signals of Seekers are generated steering signals that lead the missile to the target.
- sensors which on the movement of the Aircraft, such as inertial sensors or satellites navigation receivers, and sensors that detect targets in the field of view, such as radar and / or Infrared devices.
- sensors In a manned combat aircraft, the pilot must select a destination select a missile to attack the target and the missile to the target instruct, i. make sure the seeker has captured the target.
- the type and He will be the one or the other select another missile and shoot.
- a fast and agile target In With a short distance he will be a fast and agile missile may select a lower range. Another missile is possibly more suitable for slower targets at greater distances.
- the vote between a missile with active radar seeker and a missile with a passive infrared seeker may u. depend on the distance of the target, the Environmental conditions and the available to the opponent Countermeasures. Also critical is the time of the launch of the selected Missile.
- the pilot receives a variety of visual or audio signals from the various sensors, which he has to process and from which he has to make his decision. additionally of course, the pilot must fly the fighter jet in aerial combat. The pilot must also watch out for threats such as from enemy missiles and if necessary, avoid such threats and activate countermeasures. This can overwhelm the pilot and lead to fatal mistakes.
- This missile mission unit contains stored knowledge in the form of data and / or facts necessary for the mission of Missile are relevant. This can be data showing the characteristics of the Characterize missiles themselves, such as speed, maneuverability (maximum lateral acceleration), range, etc. This can also be data over Characteristics of potential goals.
- the missile mission unit receives data from Sensors. These are the data from your own sensors Missile. But this can also be data from sensors of the platform, e.g. the radar, or from the sensors of other missiles mounted on the platform.
- the Missile Mission Unit then provides the pilot with decision criteria for the mission Use of the associated missile. It can then be e.g. be displayed that Missile "1" is more suitable for the present situation and a specific objective as missile "2". In a manned fighter but then the pilot is the make final decision. He is, however, relieved of a lot of information. This information is preprocessed by the missile mission unit.
- missile-specific mission units can in DE 197 16 025 A1 the Missionary avionics also contain only a single mission unit, in which the Functions of the individual, missile-specific units are integrated. Preferably but is the or each missile mission unit in the associated missile arranged and connected to the platform via a standardized interface. Then is when inserting a certain type of missile into the launcher over the Automatically interface the missile mission unit designed for this type of missile switched on in the computer network. It is not an intervention in the platform-side mission avionics required.
- the invention relates to an advantageous embodiment of a missile mission unit of the type mentioned, as described by DE 197 16 025 A1 and, in particular, the training of the means for the production of plans for actions.
- the means for generating plans for actions contain means for Situation prediction, which to access the databases and on which Information is provided by the means for situational assessment and analysis, wherein the means for prediction of the situation of the target and its known Characteristics, the characteristics of the missile and the states of motion Extrapolate future situations.
- the results of the situation prediction are on means for Calculation of missile ranges, possibly with respect to the target or, if applicable, different destinations may be available for different available types of missile.
- the missile mission unit From the prediction of the future change of the situation, the missile mission unit recognize and if necessary make visible to the pilot, whether the goal of one launched missile at the flight condition of the platform (of own aircraft) can be detected or not. Does the platform carry several missiles? Types, it can be determined by the missile mission unit, which of these Missile with the best prospects of success should be shot down.
- the results of the calculation are optimal Inferential for the production of reaction proposals switched.
- These inference means are preferably of a learning capable, suitably trained neuro-fuzzy Structure formed. They contain “rules” approximately in the form: “If the goal without Another maneuver of the aircraft in the firing range of the missile is, then fire the Missile off "," If the target is slightly out of the firing range of the Is missile, then perform this or that maneuver to the target in the Shot area of the missile to bring "etc.
- the inputs" within “or “marginally outside” are linquistic inputs, which are indicated by "Fuzzy-Logic” be detected.
- the inference means give the pilot recommendations for action.
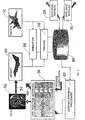
- 10 is a target, in the present case an enemy combat aircraft, designated.
- sensors are designated. These sensors 12 include a viewfinder 14 and inertial sensors 16 for determining the intrinsic movement of the target 10
- Viewfinder 14 detects the movement of the target 10 relative to the missile. The movement of the target is symbolized by a block 18. The proper motion of the missile is represented by a block 20.
- the viewfinder 14 contains a plurality of different ones Sensors. The viewfinder may u.U. "see" several objects at the same time.
- Objects and potential targets supplied data are processed by image processing Detection of objects, ie a determination of where an object is located. Furthermore, it takes place an identification of the objects with regard to friend / enemy recognition.
- image structures e.g. known types of aircraft with the image-resolving sensors supplied image structures.
- the nature of the object is detected.
- the Traced motion structures or traces of objects. The objects are classified, so that potential goals are picked out. This is through a block 22 shown.
- the missile mission unit further includes means 26 for generating plans and actions. These means 26 comprise the elements 28, 30, 32, 34, 36 and 38 in Fig.1.
- Block 28 is a database in which knowledge about potential goals is stored are. It is known what flight characteristics a type X aircraft has and which air combat tactics in a given situation usually with a Type X aircraft are applied. If the target as a type X aircraft and the situation is recognized, then one can estimate from it, how the goal in the next future is expected to behave.
- Block 34 symbolizes the evaluation of the results of block 34 shown calculations. The result of this evaluation is on inference means 38 "Switched".
- These inference means 38 are of a learning capable, suitably trained neuro-fuzzy Structure formed. They contain “rules” approximately in the form: “If the goal without further Maneuver of the aircraft in the firing range of the missile, then fire the missile from ",” If the target is slightly out of the firing range of the missile, then Perform this or that maneuver to bring the target into the firing range of the To bring missiles "etc. The inputs" within “or” slightly outside “ are thereby linquistic inputs, which are registered by "Fuzzy Logic”.
- the Inference means 38 provide recommendations to the pilot or decision element 44 to trade. These recommendations are indicated in the figure by a parallelogram 46 shown.
- Figure 2 illustrates the acquisition of the required knowledge by the lemimple Inference.
- the adaptive inference unit may be from aerial combat simulations or real Air combat training automatically acquire realistic knowledge. That is the Prerequisite for correct and effective conclusions.
- the own aircraft is designated 50.
- the reference numeral 10 denotes again the goal or the goals.
- the own plane 50 becomes real or in one Simulation controlled by the pilot 52, as shown by arrow 54.
- simulation data or training data is transmitted the situational behavior of attackers, i. own plane 50, and destination 10 and generated via a simulated missile mission.
- This simulation and / or Training data is stored in a data memory 60.
- the behavior of the attacker is essentially determined by the recommendations of the inference unit 38 and thus by the knowledge stored therein in the form of rules.
- the inference unit 38 is constructed as a fuzzy-neural network.
- a set of rules representing heuristic prior knowledge is stored and processed a priori in the inference means.
- the fuzzy-neural network of the inferring unit is continuously further trained on the basis of the rules stored a priori .
- This is done according to known learning strategies and procedures, which are shown in Fig.2 by a block 62.
- An arrow 64 symbolizes the change of the fuzzy-neural network of the inference unit 38.
- the recorded data in the data memory 60 is also used to store the To complete and update databases 28 and 30 on targets and missiles.
Landscapes
- Engineering & Computer Science (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- General Engineering & Computer Science (AREA)
- Aiming, Guidance, Guns With A Light Source, Armor, Camouflage, And Targets (AREA)
Description
- Fig.1
- ist ein Blockdiagramm einer Struktur des Ablaufs vom Erkennen eines Ziels bis zur Reaktion durch den Piloten oder ein "Entscheidungselement" im Falle eines unbemannten Trägers.
- Fig.2
- veranschaulicht den Erwerb von Wissen durch die Inferenzmittel bei einer Struktur von Fig.1.
Claims (6)
- Flugkörper-Missionseinheit für einen Flugkörper (10), auf welche Sensoren (12,14,16) für die Bewegung (18) eines Ziels (10) relativ zu dem Flugkörper (42) und für die Eigenbewegung (20) des Flugkörpers (42) aufgeschaltet sind, enthaltend(a) Mittel (22) zur Detektion und Identifikation und zur Bestimmung der Spur des Ziels, die von Daten der Sensoren beaufschlagt sind,(b) Mittel (24) zur Situations-Bewertung und -Analyse aus den Informationen über Ort, Art und Spur des Ziels,(c) eine erste Datenbank (28), in welcher Kenntnisse über potentielle Ziele gespeichert sind,(d) eine zweite Datenbank (30), in welcher Daten über die Fähigkeiten der Flugkörper gespeichert sind, und(e) Mittel (26) zur Erzeugung von Plänen für Aktionen und daraus zur Erzeugung von Entscheidungs-Kriterien,
dadurch gekennzeichnet, daß(f) die Mittel (26) zur Erzeugung von Plänen für Aktionen Mittel (32) zur Situations-Vorhersage enthalten, welche auf die Datenbanken (28,30) .zugreifen und auf welche Informationen von den Mitteln (24) zur Situationsbewertung und -analyse aufgeschaltet sind, wobei die Mittel (32) zur Situationsvorhersage aus der Art des Ziels und seiner bekannten Eigenschaften, den Eigenschaften des Flugkörpers und den Bewegungszuständen auf zukünftige Situationen extrapolieren. - Flugkörper-Missionseinheit nach Anspruch 1, dadurch gekennzeichnet, daß die Ergebnisse der Situations-Vorhersage auf Mittel (34) zur Berechnung von Flugkörper-Reichweiten (40,40A,40B) ggf. in bezug auf das Ziel (10) oder ggf. verschiedene Ziele ggf. für verschiedene verfügbare Flugkörpertypen aufgeschaltet sind.
- Flugkörper-Missionseinheit nach Anspruch 2, dadurch gekennzeichnet, daß die Ergebnisse der Berechnung auf optimale Inferenzmittel (38) zur Erzeugung von Reaktionsvorschlägen (46) aufgeschaltet sind.
- Flugkörper-Missionseinheit nach Anspruch 3, dadurch gekennzeichnet, daß die Reaktionsvorschläge auf eine Mensch-Maschine-Schnittstelle aufgeschaltet sind.
- Flugkörper-Missionseinheit nach Anspruch 3, dadurch gekennzeichnet, daß(a) ein Datenspeicher (60) vorgesehen ist, in welchem bei Simulation oder realem Luftkampftraining gewonnene Daten speicherbar sind,(b) die Inferenzmittel (38) von einem fuzzy-neuronalen Netz gebildet sind und(c) Lernverfahrensmittel (62) vorgesehen sind, durch welche das fuzzy-neuronale Netz durch Training mit den gespeicherten Daten modifizierbar ist, derart daß Regeln und/oder Zugehörigkeitsfunktionen der Inferenzmittel (38) laufend an aktuelle Gegebenheiten anpaßbar sind.
- Flugkörper-Missionseinheit nach Anspruch 5, dadurch gekennzeichnet, daß Datenbanken (28,30) der Mittel (32) zur Situations-Vorhersage durch die in dem Datenspeicher (60) gespeicherten Simulations- oder Trainingsdaten aktualisierbar sind.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE19942139A DE19942139A1 (de) | 1999-09-03 | 1999-09-03 | Flugkörper-Missionseinheit |
| DE19942139 | 1999-09-03 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP1087200A1 EP1087200A1 (de) | 2001-03-28 |
| EP1087200B1 true EP1087200B1 (de) | 2005-01-19 |
Family
ID=7920728
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP00116828A Expired - Lifetime EP1087200B1 (de) | 1999-09-03 | 2000-08-04 | Flugkörper-Missionseinheit |
Country Status (2)
| Country | Link |
|---|---|
| EP (1) | EP1087200B1 (de) |
| DE (2) | DE19942139A1 (de) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US8779920B2 (en) | 2008-01-21 | 2014-07-15 | Thales Nederland B.V. | Multithreat safety and security system and specification method thereof |
| CN107203493A (zh) * | 2017-06-09 | 2017-09-26 | 西北工业大学 | 基于复杂比例评价方法的多目标态势估计方法 |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE10129043A1 (de) * | 2001-06-15 | 2003-01-02 | Diehl Munitionssysteme Gmbh | Verfahren und Vorrichtungen zum Bestimmen des Auslösens einer Bremseinrichtung für die zielbezogene Korrektur der ballistischen Flugbahn eines Projektils |
| CN102663430B (zh) * | 2012-04-17 | 2013-11-27 | 清华大学 | 一种态势评估中目标分群方法 |
| DE102022001289A1 (de) | 2022-04-13 | 2023-10-19 | Diehl Defence Gmbh & Co. Kg | Verfahren zum Ausweichen eines Flugkörpers vor einem Abfangflugkörper |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE3640427A1 (de) * | 1986-12-01 | 1988-06-09 | Siemens Ag | Raketenabwehrsystem |
| DE4130164A1 (de) * | 1991-09-11 | 1993-03-18 | Bodenseewerk Geraetetech | Regler, insbesondere flugregler |
| DE4339606A1 (de) * | 1993-11-20 | 1995-05-24 | Bodenseewerk Geraetetech | Piloten-Trainingsgerät |
| DE19716025B4 (de) | 1997-04-17 | 2009-12-03 | Diehl Bgt Defence Gmbh & Co. Kg | Plattform mit abschießbaren, zielverfolgenden Flugkörpern, insbesondere Kampfflugzeug |
-
1999
- 1999-09-03 DE DE19942139A patent/DE19942139A1/de not_active Withdrawn
-
2000
- 2000-08-04 EP EP00116828A patent/EP1087200B1/de not_active Expired - Lifetime
- 2000-08-04 DE DE50009264T patent/DE50009264D1/de not_active Expired - Lifetime
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US8779920B2 (en) | 2008-01-21 | 2014-07-15 | Thales Nederland B.V. | Multithreat safety and security system and specification method thereof |
| CN107203493A (zh) * | 2017-06-09 | 2017-09-26 | 西北工业大学 | 基于复杂比例评价方法的多目标态势估计方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| DE50009264D1 (de) | 2005-02-24 |
| DE19942139A1 (de) | 2001-03-08 |
| EP1087200A1 (de) | 2001-03-28 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| Zijian et al. | Relevant experience learning: A deep reinforcement learning method for UAV autonomous motion planning in complex unknown environments | |
| CN113282061A (zh) | 一种基于课程学习的无人机空中博弈对抗的解决方法 | |
| Zhang et al. | Maneuver decision-making of deep learning for UCAV thorough azimuth angles | |
| CN112051863A (zh) | 一种无人机自主反侦察及躲避敌方攻击的方法 | |
| CN113139331A (zh) | 一种基于贝叶斯网络的空空导弹态势感知与决策方法 | |
| DE69931216T2 (de) | Flugbahnbefehlssteuerung mit neuronalem netzwerk | |
| Qiu et al. | One-to-one air-combat maneuver strategy based on improved TD3 algorithm | |
| Blair et al. | The Swarm, the Cloud, and the Importance of Getting There First. | |
| CN113741186B (zh) | 一种基于近端策略优化的双机空战决策方法 | |
| CN119556722A (zh) | 一种基于分层强化学习的无人机空战对抗方法 | |
| CN118838408A (zh) | 单元配合知识增强的异构无人机编队自主决策实现方法 | |
| EP1014028B1 (de) | Lenk,- Navigations- und Regelsystem für Flugkörper | |
| McIntosh | The Wingman-Philosopher of MiG Alley | |
| EP0654776B1 (de) | Piloten-Trainingsgerät | |
| EP1087200A1 (de) | Flugkörper-Missionseinheit | |
| DE19645556A1 (de) | Vorrichtung zur Erzeugung von Lenksignalen für zielverfolgende Flugkörper | |
| DE19716025B4 (de) | Plattform mit abschießbaren, zielverfolgenden Flugkörpern, insbesondere Kampfflugzeug | |
| Chao et al. | An air combat simulation system for intelligent decision-making | |
| Blair | A Categorical Error: Rethinking'Drones' as an Analytical Category for Security Policy | |
| Tirpak | The robotic air force | |
| Chunmei et al. | Recognition of flight operation action based on expert system inference engine | |
| Zhang et al. | Intelligent close air combat design based on MA-POCA algorithm | |
| Hu et al. | An Intelligent MAV-UAV Cooperative Combat Planning Method Based on Deep Reinforcement Learning | |
| Harshina | Generating UAV Countermeasures using Machine Learning: A Game-Based Approach | |
| Rulko | Actor complexification in TD3 and curriculum learning with structural composition for drone countering |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| 17P | Request for examination filed |
Effective date: 20001223 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): DE FR GB SE |
|
| AX | Request for extension of the european patent |
Free format text: AL;LT;LV;MK;RO;SI |
|
| AKX | Designation fees paid |
Free format text: DE FR GB SE |
|
| 17Q | First examination report despatched |
Effective date: 20030930 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): DE FR GB SE |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REF | Corresponds to: |
Ref document number: 50009264 Country of ref document: DE Date of ref document: 20050224 Kind code of ref document: P |
|
| RAP2 | Party data changed (patent owner data changed or rights of a patent transferred) |
Owner name: DIEHL BGT DEFENCE GMBH & CO.KG |
|
| REG | Reference to a national code |
Ref country code: SE Ref legal event code: TRGR |
|
| GBT | Gb: translation of ep patent filed (gb section 77(6)(a)/1977) |
Effective date: 20050525 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| ET | Fr: translation filed | ||
| 26N | No opposition filed |
Effective date: 20051020 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20050831 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST Effective date: 20111007 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20140820 Year of fee payment: 15 Ref country code: SE Payment date: 20140820 Year of fee payment: 15 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20141022 Year of fee payment: 15 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R119 Ref document number: 50009264 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: SE Ref legal event code: EUG |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20150804 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20150805 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20160301 Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20150804 |