PCB circuit board packagine machine
Technical Field
The invention relates to the field of circuit board packaging, in particular to a PCB packaging machine.
Background
PCB circuit board often need pass through the process of packing after production, and traditional PCB circuit board packing is wrapped up the PCB circuit board after arranging through the machine of special packing with the bubble membrane, realizes sealed the sealing through the hot melt, vanning afterwards.
For example, chinese patent application No. CN201810150715.3 discloses "an automatic bubble film packaging machine on PCB carrier and its operation method", the packaging machine can automatically place the bubble film on the PCB carrier by the cooperation of the pressing mechanism, the cutting mechanism, the pulling mechanism, the clamping mechanism and the control panel, and can perform packaging and cutting without manual feeding, thereby reducing the amount of manual labor and the production cost; for example, chinese patent application No. CN202010011221.4 discloses a full-automatic bubble film packaging PCB finished product machine, which can automatically place a PCB finished product in a bubble film bag formed by heat sealing and cutting, and also realizes automatic sealing, cutting and packaging. Although the packaging method adopting the bubble film can realize the packaging of the PCB, the packaging method adopting the bubble film needs complicated winding actions, and also needs to prepare raw materials such as the bubble film, which is very inconvenient and greatly reduces the packaging efficiency.
As shown in fig. 1 and 2, schematic diagrams of the produced PCB are shown, wherein the PCB in fig. 1 is placed in the tray, the first surface 101 faces upward, the PCB is provided with a liquid crystal screen 103 on the first surface 101, and in fig. 2, the second surface 102 of the PCB is provided with a transformer 104. The state of PCB circuit board should be that second face 102 is up during the transport, and the state that first face 101 is down is about to the LCD screen 103 parcel in the carriage, avoids the transportation to cause LCD screen 103 to damage.
Disclosure of Invention
The first technical problem to be solved by the invention is to provide a PCB circuit board packaging machine for realizing automatic feeding, overturning and discharging stacking of PCB circuit boards aiming at the current situation of the prior art.
A second technical problem to be solved by the present invention is to provide a PCB packaging machine capable of turning a PCB before loading, in view of the current situation of the prior art.
The third technical problem to be solved by the invention is to provide a PCB packaging machine which can respectively grab a PCB and a blister tray by only one material clamping device, aiming at the current situation of the prior art.
The fourth technical problem to be solved by the invention is to provide a PCB packaging machine which can smoothly feed plastic sucking discs when a box body bearing the plastic sucking discs is positioned between a first conveying table and a transfer table and between a second conveying table of the transfer table, aiming at the current situation of the prior art.
The technical scheme adopted by the invention for solving the first technical problem is as follows: a PCB circuit board packing machine comprising:
a frame;
the frame has the transfer table that is used for placing PCB circuit board on the plastic sucking dish, still includes:
the turnover mechanism is arranged on the rack and used for taking out the PCB in the tray and turning the taken-out PCB from the first surface to the second surface upwards;
the first conveying platform is used for conveying empty plastic sucking discs to the transfer platform, is arranged on one side of the transfer platform, and has an outlet end connected with an inlet end of the transfer platform;
the second conveying platform is arranged at the downstream of the transfer platform along the conveying direction of the plastic sucking discs, and the inlet end of the second conveying platform is connected with the outlet end of the transfer platform;
and the clamping device is arranged above the transfer table, the output end of the clamping device is provided with a grabbing mechanism which is used for grabbing the PCB and can move back and forth between the material overturning mechanism and the transfer table, and the clamping device is used for grabbing the PCB after the material overturning mechanism is overturned and placing the PCB in the plastic sucking disc corresponding to the transfer table.
In order to ensure that the clamping mechanism in the clamping device can reasonably move back and forth between the turning mechanism and the transfer platform, preferably, the first conveying platform and the second conveying platform are arranged side by side on the same side of the transfer platform, the material conveying directions of the first conveying platform and the second conveying platform are opposite, the material conveying direction of the transfer platform is perpendicular to the material conveying directions of the first conveying platform and the second conveying platform, and the turning mechanism is arranged on the other side of the transfer platform.
In order to ensure that the PCB boards contained in the tray can be conveyed to the material turnover mechanism, preferably, the material turnover mechanism has a material conveying table, and the material conveying table has a first conveying belt for conveying the tray containing the PCB boards to the material turnover mechanism and a second conveying belt for outputting the empty tray.
In order to further solve the second technical problem and realize the turnover of the PCB, the invention adopts the following technical scheme: the turnover assembly further comprises a turnover table plate with a negative pressure sucker and a first driving mechanism, a support frame is arranged at a position, close to an outlet of the first conveying belt, the turnover table plate is rotatably arranged on the support frame, a rotating axis of the turnover table plate extends along the conveying direction of the PCB, and a power output end of the first driving mechanism is in driving connection with the turnover table plate so as to drive the turnover table plate to rotate.
The overturning action of the overturning platen can adopt different forms, preferably, the number of the supporting frames is two, the two supporting frames are arranged at intervals along the conveying direction of the PCB, and the overturning platen is arranged between the two supporting frames; each the bearing frame has seted up the shaft hole separately in corresponding position, the both ends of upset platen all are equipped with the positioning seat, and to every positioning seat, all protruding pivot portion that is equipped with shaft hole looks adaptation in one side of neighbouring corresponding shaft hole, thereby the upset platen rotates through pivot portion and the relative support frame of cooperation that corresponds the shaft hole, realizes the upset action through positioning seat and support frame cooperation like this, and the reliability of upset is ensured in the shared space of reduction upset that can the at utmost.
In order to facilitate the grabbing of the turnover table board on the PCB to be turned over, preferably, a chute is formed in one side of the positioning seat adjacent to the turnover table board, two ends of the turnover table board are respectively provided with a sliding block matched with the corresponding chute, a second driving mechanism is further arranged above the turnover table board, and a power output end of the second driving mechanism is in driving connection with the turnover table board so as to drive the turnover table board to slide back and forth relative to the positioning seat through the sliding matching of the sliding block and the chute, so that the turnover table board can drive the negative pressure suction cup to synchronously move up and down relative to the plastic sucking disc moving to the turnover mechanism before and after being turned over.
In order to further solve the third technical problem and realize the movement of the clamping device to the PCB and the plastic sucking disc, the invention adopts the technical scheme that: press from both sides material device still including the cantilever, this cantilever is located in the frame and is arranged the top of transfer table, it connects to snatch the mechanism on the cantilever, should snatch the mechanism and include first clamping jaw and second clamping jaw, wherein:
the first clamping jaw is used for grabbing the plastic sucking disc at the first material loading position onto the transfer table;
the second clamping jaws are arranged at intervals in the circumferential direction of the first clamping jaw and used for grabbing the PCB at the second loading position onto the plastic sucking disc, and the PCB to be assembled on the assembly line and the plastic sucking disc are respectively grabbed through the first clamping jaw and the second clamping jaw of the grabbing mechanism, so that the first clamping jaw and the second clamping jaw are restrained by the cantilever while realizing respective functions, and mutual interference caused by respective grabbing actions is avoided.
In order to facilitate adjustment of the angle and the posture of the PCB when the PCB is transferred to the plastic sucking disc, preferably, the first clamping jaw and the second clamping jaw are both connected to the cantilever through a mounting plate, a connecting shaft is disposed at the bottom of the cantilever, a shaft hole for the connecting shaft to pass through is disposed on the mounting plate, and the plastic sucking disc further comprises a third driving mechanism, a power output end of the third driving mechanism is in driving connection with the connecting shaft, so that the mounting plate is driven to drive the first clamping jaw and the second clamping jaw to synchronously rotate relative to the frame by taking the axis of the connecting shaft as a shaft.
In order to further ensure that the centre gripping of PCB circuit board is stable, first clamping jaw has the holder and is used for holding the first sucking disc at transformer top, the power take off end of holder has two clamping pieces of mutual disposition, two form the centre gripping interval that is used for centre gripping transformer side cloth between the clamping piece, and two the clamping piece can be in opposite directions or the back of the body removes and then presss from both sides tight or unclamp the transformer on the PCB board, first sucking disc is arranged in the top of holder, and its vertical projection falls in the centre gripping interval, like this before two clamping piece centre gripping transformers, can hold through the sucking disc and carry out preliminary location, ensure the packing position of PCB circuit board.
In order to realize the clamping of the plastic sucking disc, preferably, the first clamping jaw further comprises a first lifting plate and a first cylinder, the clamping piece and the first plastic sucking disc are both connected to the first lifting plate, the power output end of the first cylinder is in driving connection with the first lifting plate, and then the first lifting plate is driven to move the clamping piece and the first plastic sucking disc up and down synchronously.
In order to can also compromise the snatching of plastic sucking disc when snatching PCB circuit board, the second clamping jaw includes second cylinder, second sucking disc and second lifter plate, the second sucking disc is connected on the second lifter plate, the power take off end of second cylinder with the second lifter plate drive is connected, and then drives second lifter plate and second sucking disc and reciprocates in step.
In order to further solve the fourth technical problem and ensure that the box body loaded with the plastic sucking disc can be transferred from the first conveying platform to the transfer platform according to the process, and then transferred from the transfer platform to the second conveying platform after being loaded, the invention adopts the technical proposal that: the packaging machine further comprises two groups of transfer mechanisms, wherein the two groups of transfer mechanisms are respectively arranged at the inlet end and the outlet end of the transfer table and are used for conveying the plastic sucking disc at the outlet end of the first conveying table to the transfer table or conveying the plastic sucking disc at the outlet end of the transfer table to the second conveying table.
Specifically, the transfer mechanism comprises a feeding seat and a first lifting assembly, a supporting plate is arranged on the transfer table, the feeding seat is arranged above the supporting plate, the first lifting assembly is provided with a first driver, and a power output end of the first driver is in driving connection with the feeding seat so as to drive the feeding seat to move up and down relative to the supporting plate.
In order to further ensure that the transfer mechanism cannot interfere with the conveying of the box body when not in use, the feeding seat is provided with a bottom plate, an output shaft of the first driver is connected onto the bottom plate, the first lifting assembly further comprises a guide rod arranged on the supporting plate, a sliding sleeve matched with the guide rod is arranged on the bottom plate, and the feeding seat is matched with the guide rod in a sliding manner through the sliding sleeve on the bottom plate of the feeding seat and the guide rod so as to move up and down relative to the supporting plate.
As an improvement, the feeding seat further comprises a second driver and two side plates, the extending direction of the two side plates is perpendicular to the advancing direction of the plastic sucking disc on the transfer table and is arranged at intervals along the advancing direction of the plastic sucking disc, third driving wheels are arranged at the front end and the rear end of each side plate, the second driver is arranged between the two side plates, an output shaft of the second driver is connected with a fourth driving wheel, the second driver sequentially winds the feeding belts arranged on the fourth driving wheel and the two third driving wheels to drive the fourth driving wheel and the two third driving wheels to be linked, and then the feeding belts are used for conveying the corresponding plastic sucking discs, so that the conveying of the box body can be further ensured through the design of the feeding belts.
Compared with the prior art, the invention has the advantages that: in the PCB circuit board packaging machine, an empty plastic sucking disc is conveyed to a transfer table through a first conveying table, a PCB circuit board in a material disc is taken out through a material turning mechanism, the taken PCB circuit board is turned over from a first surface to a second surface, and then the PCB circuit board after turning over is grabbed and placed in a corresponding plastic sucking disc on the transfer table through a grabbing mechanism which can move back and forth between the material turning mechanism and the transfer table in a material clamping device, and a box body fully loaded with the plastic sucking disc is conveyed away through a second conveying table; through the packaging form with PCB circuit board upset, snatching and placing like this, for the packaging mode of original membrane package heat-seal, not only need not the consumptive material of membrane package, and need not to set up complicated drive linkage part, stable in structure, and the plastic sucking dish can design the hole site that closes to be suitable for PCB circuit board, and maximum PCB has avoided the LCD screen that PCB circuit board leads to when carrying to damage.
Drawings
FIG. 1 is a schematic view of a tray (containing PCB circuit boards) in the present embodiment;
FIG. 2 is a schematic diagram of the PCB of the present embodiment after being flipped;
FIG. 3 is a schematic view of the whole of the blister tray in this embodiment;
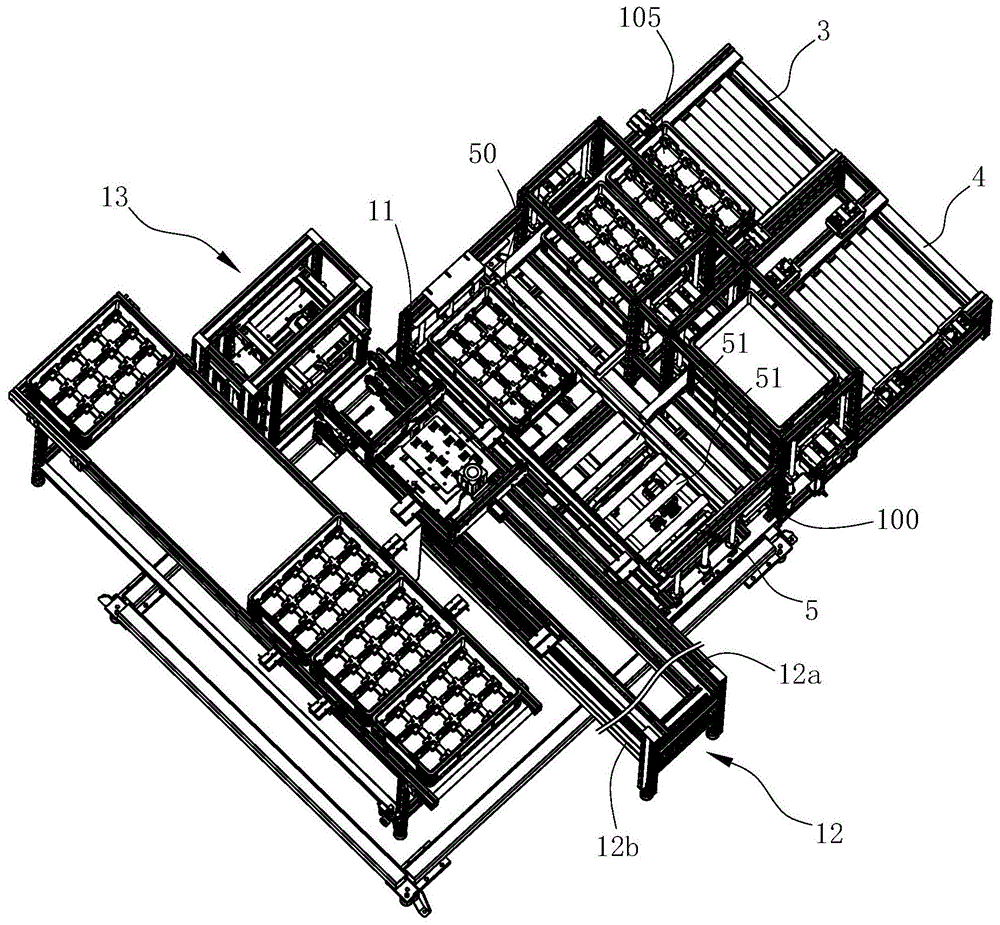
fig. 4 is a schematic view of the PCB packaging machine of the present embodiment without the material clamping device;
fig. 5 is a schematic view of the whole structure of the PCB packaging machine of the present embodiment with a part of the structure omitted;
FIG. 6 is a schematic view of the overall structure of the material clamping device in this embodiment;
FIG. 7 is an enlarged view of the structure at A in FIG. 6;
FIG. 8 is a schematic view of the structure of FIG. 6 from another angle;
FIG. 9 is an overall view of the material reversing mechanism according to the present embodiment;
FIG. 10 is an overall view from another angle of FIG. 9;
FIG. 11 is an enlarged view taken at A in FIG. 10;
FIG. 12 is an overall schematic view of the flipping platen;
FIG. 13 is an overall view of the swing mechanism in the present embodiment;
FIG. 14 is a schematic view from another angle of FIG. 13;
FIG. 15 is a general schematic view of the PCB packaging machine without the material turning mechanism and the material clamping device;
FIG. 16 is a schematic view of the first angle of FIG. 15;
FIG. 17 is a schematic view of the structure of FIG. 15 at a second angle;
fig. 18 is an overall schematic view of the relay mechanism;
FIG. 19 is a schematic view from another angle of FIG. 18;
fig. 20 is an enlarged schematic view at a in fig. 17.
Detailed Description
The invention is described in further detail below with reference to the accompanying examples.
As shown in fig. 1 to 20, which are preferred embodiments of the present invention, in the present embodiment, the PCB circuit board packaging machine includes a frame 100, a material turning mechanism 11, a first transfer table 3, a second transfer table 4, and a material clamping device.
The frame 100 has a transfer table 50 for placing the PCB on the blister tray 105, and the material turnover mechanism 11 is disposed on the frame 100 for taking out the PCB from the blister tray and turning the taken-out PCB from the first side 101 to the second side 102. In this embodiment, the two blister trays 105 are generally stacked and loaded in a single box, the first transfer station 3 is arranged on one side of the transfer station 50 for transferring the empty blister trays 105 to the transfer station 50, i.e. for transferring the box loaded with the blister trays 105 to the transfer station, the first transfer station 3 is arranged on an inlet side of the transfer station 50, an outlet end of the first transfer station is connected to an inlet end of the transfer station 50, the second transfer station 4 is arranged for transferring the blister trays 105 containing the loaded PCB boards away from the transfer station 50, the second transfer station 4 is arranged downstream of the transfer station 50 in the transfer direction of the blister trays 105, an inlet end of the second transfer station is connected to an outlet end of the transfer station 50, the positions of the first transfer station 3 and the second transfer station 4 and the transfer station 50 may be different, in this embodiment, the first transfer station 3 and the second transfer station 4 are arranged side by side on the same side of the transfer station 50, and the first transfer station 3 and the second transfer station 4 are opposite in the transfer direction, the material conveying direction of the transfer platform 50 is perpendicular to the material conveying direction of the first conveying platform 3 and the second conveying platform 4, and the material overturning mechanism 11 is arranged on the other side of the transfer platform 50. The feeding, loading and stacking form a U-shaped assembly line, no extra space is occupied, and the device is very convenient and fast. In this embodiment, the above-mentioned material clamping device is used to sequentially clamp and place the PCB after being turned over by the material turning mechanism 11 into the tray 105 corresponding to the transfer platform 50, and the material clamping device is disposed above the transfer platform 50 and has a gripping mechanism 20 at its output end for gripping the PCB and capable of moving back and forth between the material turning mechanism 11 and the transfer platform 50.
Referring to fig. 9 to 14, in particular, the material turning mechanism 11 has a material conveying platform 12, the material conveying platform 12 has a first conveying belt 12a for conveying trays containing PCB circuit boards to the material turning mechanism 11 and a second conveying belt 12b for outputting empty trays, the first conveying belt 12a and the second conveying belt 12b may be arranged side by side or in other positions, and in order to save space, the first conveying belt 12a and the second conveying belt 12b are arranged up and down, and the material turning mechanism 11 is arranged above the first conveying belt 12a and adjacent to an outlet of the first conveying belt 12 a.
In this embodiment, in order to turn the PCB, the turning assembly 110 includes a turning platen 111 and a first driving mechanism 112, the first conveyor belt 12a is provided with a support frame 113 at a position adjacent to the outlet thereof, the turning platen 111 is rotatably disposed on the support frame 113, a rotation axis of the turning platen 111 extends along a conveying direction of the PCB, and a power output end of the first driving mechanism 112 is drivingly connected to the turning platen 111 to drive the turning platen 111 to rotate. Specifically, there are two support frames 113, the two support frames 113 are arranged at intervals along the conveying direction of the PCB, and the flipping board 111 is disposed between the two support frames 113. Shaft holes are respectively formed in the corresponding positions of the support frames 113, positioning seats 114 are respectively arranged at two ends of the turnover bedplate 111, a rotating shaft part 115 matched with the shaft holes is convexly arranged on one side of each positioning seat 114, which is adjacent to the corresponding shaft hole, and the turnover bedplate 111 rotates relative to the support frames 113 through the matching of the rotating shaft part 115 and the corresponding shaft hole.
In this embodiment, the PCB needs to be taken out from the tray before the PCB is turned over, a positioning post 17 is formed on the turning platen 111, and the vacuum chuck 15 is connected to an end of the positioning post 17. The positioning seat 114 is provided with a sliding groove 1141 at one side adjacent to the turnover bedplate 111, two ends of the turnover bedplate 111 are respectively provided with a sliding block 1142 matched with the corresponding sliding groove 1141, the turnover bedplate 111 slides back and forth relative to the positioning seat 114 through the sliding matching of the sliding block 1142 and the sliding groove 1141, so that the turnover bedplate 111 can drive the negative pressure suction cup 15 to synchronously move up and down relative to the material tray moving to the material turnover mechanism 11 before and after turnover. The movement of the negative pressure sucker 15 for taking out the PCB is realized by an independent power source, the turnover device further comprises a second driving mechanism 14, and a power output end of the second driving mechanism 14 is in driving connection with the turnover table board 111, so as to drive the turnover table board 111 to slide relative to the positioning seat 114.
In order to ensure that the tray after taking out the PCB can be reloaded, the material turning mechanism 11 further comprises a turning mechanism 13, the turning mechanism 13 is arranged downstream of the material turning mechanism 11 along the feeding direction of the tray, and the feeding port 13a corresponds to the outlet of the first conveyer 12a and the discharging port 12b corresponds to the inlet of the second conveyer 12 b. The revolving mechanism 13 includes a box 131 and a feeding seat 132 disposed in the box 131, the box 131 has a notch on a side adjacent to the conveying platform 12, the upper portion of the notch forms a feeding port 13a, the lower portion of the notch forms a discharging port 12b, a first driving source 15 is further disposed in the box 131, a power output end of the first driving source 15 is drivingly connected to the feeding seat 132, and the feeding seat 132 is further driven to move up and down in the box 131, so as to move back and forth between the feeding port 13a and the discharging port 12 b. Specifically, the feeding seat 132 includes a frame 1321, one end of the frame 1321 in the two ends of the PCB in the conveying direction is provided with a rotating shaft 1322, two ends of the rotating shaft 1322 are provided with driving wheels 1323, the other end of the frame 1321 is provided with driven wheels 1324, and the driving wheels 1323 and the driven wheels 1324 are wound with a conveyor belt 1325; the device further comprises a second driving source 16, and a power output end of the second driving source 16 is in driving connection with the rotating shaft 1322, so that the driving wheel 1323 is driven to be linked with the driven wheel 1324.
Referring to fig. 5 to 8, in the present embodiment, the material clamping device further includes a cantilever 21, the cantilever 21 is disposed on the rack 100 and is disposed above the transfer platform 11, the grabbing mechanism 20 is connected to the cantilever 21, the grabbing mechanism 20 specifically includes a first clamping jaw 22 and a second clamping jaw 23, wherein: the first clamping jaws 22 are used for grabbing the plastic sucking disc 105 at the first loading position 11a onto the transfer table 11, and the second clamping jaws 23 are at least two and are arranged at intervals in the circumferential direction of the first clamping jaws 22 and used for grabbing the PCB circuit board at the second loading position 11b onto the plastic sucking disc 105.
The number of the second clamping jaws 23 can be adjusted according to the size of the plastic sucking disc 105 and the packing distribution of the PCB, and in order to ensure stable material transportation, the number of the second clamping jaws 23 in this embodiment is four and is arranged at intervals along the circumference of the first clamping jaw 22, that is, the four second clamping jaws 23 are arranged near the position where the plastic sucking disc 105 is grabbed by the four second clamping jaws 23, which is favorable for the stability of the whole plastic sucking disc 105.
In this embodiment, the first clamping jaw 22 and the second clamping jaw 23 are both connected to the cantilever 21 through the mounting plate 24, the bottom of the cantilever 21 is provided with the connecting shaft 251, and the mounting plate 24 is provided with a shaft hole for the connecting shaft 251 to pass through. In fact, the connection manner of the connection shaft 251 is equivalent to a rotating shaft, which can allow the mounting plate 24 and the first clamping jaw 22 and the second clamping jaw 23 connected thereto to synchronously rotate relative to the cantilever 21. Such a rotatable connection has the advantage that when PCB boards need to be boxed, once the clamped angle is not correct, the offset angle can be compensated by rotation, thereby ensuring that each PCB board can be aligned with a hole site on the blister tray 105. Of course, the rotation of the installation plate 4 can be driven in different forms, in this embodiment, the third driving mechanism 252 is used as a power source, a power output end of the third driving mechanism 252 is connected to the connecting shaft 251 in a driving manner, and then the installation plate 24 is driven to drive the first clamping jaw 22 and the second clamping jaw 23 to synchronously rotate relative to the frame by using the axis of the connecting shaft 251 as a shaft. Specifically, a gear plate 253 is coaxially connected to the connecting shaft 251, and a rack 254 is connected to an output shaft of the third driving mechanism 252, and the rack 254 is engaged with the gear plate 253.
In this embodiment, because the materials to be clamped are different, the above-mentioned first clamping jaw 22 and second clamping jaw 23 are also slightly different in arrangement form, wherein the first clamping jaw 22 has a clamping member 221, a power output end of the clamping member 221 has two clamping pieces 222 arranged oppositely, a clamping area 22a for clamping the transformer side cloth is formed between the two clamping pieces 222, and the two clamping pieces 222 can move toward or away from each other to clamp or release the transformer 104 on the PCB board. In addition, the first clamping jaw 22 further comprises a first suction pad 223 for holding the top of the transformer, the first suction pad 223 is arranged above the clamping member 221, and the vertical projection of the first suction pad 223 falls within the clamping interval 22 a. The first clamping jaw 22 further includes a first lifting plate 224 and a first cylinder 225, the clamping member 221 and the first suction cup 223 are both connected to the first lifting plate 224, and a power output end of the first cylinder 225 is in driving connection with the first lifting plate 224, so as to drive the first lifting plate 224 to drive the clamping member 221 and the first suction cup 223 to move up and down synchronously.
The second clamping jaw 23 includes a second cylinder 231, a second suction cup 232 and a second lifting plate 233, the second suction cup 232 is connected to the second lifting plate 233, and a power output end of the second cylinder 231 is in driving connection with the second lifting plate 233, so as to drive the second lifting plate 233 and the second suction cup 232 to move up and down synchronously.
In addition, in order to facilitate the grabbing mechanism 20 to move back and forth between the transfer platform 50 and the material turning mechanism 11, the first clamping jaw 22 and the second clamping jaw 23 are both connected to the cantilever 21 through the sliding base 27, that is, the grabbing mechanism 20 is connected to the sliding base 27, the cantilever 21 is further provided with the driving motor 26, the power output end of the driving motor 26 is in driving connection with the sliding base 27, and further the sliding base 27, the first clamping jaw 22 and the second clamping jaw 23 are driven to synchronously slide back and forth along the cantilever 21.
Referring to fig. 15 to 20, in the present embodiment, in order to facilitate the transfer of the box body carrying the blister tray 105 from the first conveying table 3 to the transfer table 50 and then from the transfer table 50 to the second conveying table 4, the packaging machine further includes two transfer mechanisms 5, in the present embodiment, two sets of transfer mechanisms 5 are respectively disposed at the inlet end and the outlet end of the transfer table 50, and are used for transferring the blister tray 105 at the outlet end of the first conveying table 3 to the transfer table 50 or transferring the blister tray 105 at the outlet end of the transfer table 50 to the second conveying table 4.
Specifically, the transfer mechanism 5 includes a feeding base 52 and a first lifting assembly 53, the transfer table 50 is provided with a supporting plate 54, the feeding base 52 is disposed above the supporting plate 54, the first lifting assembly 53 has a first driver 531, a power output end of the first driver 531 is in driving connection with the feeding base 52, and the feeding base 52 is driven to move up and down relative to the supporting plate 54. The feeding base 52 has a bottom plate 521, an output shaft of the first driver 531 is connected to the bottom plate 521, the first lifting assembly 53 further includes a guide rod 532 disposed on the support plate 54, a sliding sleeve 522 matched with the guide rod 532 is disposed on the bottom plate 521, and the feeding base 52 moves up and down relative to the support plate 54 through the sliding fit between the sliding sleeve 522 on the bottom plate 521 and the guide rod 532. The feeding base 52 further comprises a second driver 523 and two side plates 524, the extending direction of the two side plates 524 is perpendicular to the advancing direction of the plastic sucking disc 105 on the transfer table 50, and the two side plates are arranged at intervals along the advancing direction of the plastic sucking disc 105, each side plate 524 is provided with third driving wheels 525 at the front end and the rear end thereof, the second driver 523 is arranged between the two side plates 524, an output shaft of the second driver is connected with a fourth driving wheel 526, and the second driver 523 drives the fourth driving wheel 526 and the two third driving wheels 525 to be linked through a feeding belt 527 sequentially wound on the fourth driving wheel 526 and the two third driving wheels 525, so that the feeding belt 527 can convey the corresponding plastic sucking disc 105.
The working process of the PCB packaging machine is as follows:
the whole PCB is packaged in two steps, wherein the first step is to turn the PCB over, and the second step is to grab the turned PCB into the blister tray 105 of the transfer table 50.
When the automatic material taking and placing device works, a tray loaded with the PCB is conveyed to the position of the turnover table plate 11 by the first conveying belt 12a, at the moment, the turnover table plate 11 moves downwards under the driving of the second driving mechanism 14, the corresponding PCB can be grabbed by the negative pressure suction cups 15 arranged on the turnover table plate, then the turnover table plate 11 is reset to the original height, and is turned over to the position above the turnover table plate 11, namely the state that the second surface 102 faces upwards under the driving of the first driving mechanism 112, and the grabbing mechanism 20 is waited to grab.
While the PCB is conveyed, the box body bearing the plastic sucking disc 105 is conveyed to the transfer table 50 by the first conveying table 3, two stacked plastic sucking discs 105 are contained in each box body, the overturned PCB is clamped by the first clamping jaw 22 in the grabbing mechanism 20 and is sequentially placed in each hole site of the plastic sucking disc 105. In the whole production line, only one plastic sucking disc 105 is contained in the box body at the forefront end, when the plastic sucking disc 105 is full of PCB, the plastic sucking disc is directly loaded into the next box body continuously, because the second box body is internally provided with two plastic sucking discs 105 which are overlapped, when the upper layer of the plastic sucking disc 105 is fully loaded, the second clamping jaw 23 in the grabbing mechanism 20 grabs the plastic sucking disc 105 and places the plastic sucking disc 105 into the previous box body, so that the two plastic sucking discs 105 which are overlapped exist in the first box body, and only one plastic sucking disc 105 exists in the second box body, and the steps are circulated again, so that each output box body is provided with two plastic sucking discs 105 which are fully loaded, and the packaging process of the PCB is further completed.