CN111292598A - Anesthesia technology operation training model - Google Patents
Anesthesia technology operation training model Download PDFInfo
- Publication number
- CN111292598A CN111292598A CN201910739451.XA CN201910739451A CN111292598A CN 111292598 A CN111292598 A CN 111292598A CN 201910739451 A CN201910739451 A CN 201910739451A CN 111292598 A CN111292598 A CN 111292598A
- Authority
- CN
- China
- Prior art keywords
- telescopic rod
- electric telescopic
- training model
- fixedly installed
- fixedly connected
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
- 238000012549 training Methods 0.000 title claims abstract description 58
- 206010002091 Anaesthesia Diseases 0.000 title claims abstract description 24
- 230000037005 anaesthesia Effects 0.000 title claims abstract description 24
- 238000005516 engineering process Methods 0.000 title description 3
- 230000007246 mechanism Effects 0.000 claims abstract description 46
- 230000005540 biological transmission Effects 0.000 claims abstract description 18
- 238000000034 method Methods 0.000 claims abstract description 17
- 230000001681 protective effect Effects 0.000 claims abstract description 15
- VYPSYNLAJGMNEJ-UHFFFAOYSA-N Silicium dioxide Chemical compound O=[Si]=O VYPSYNLAJGMNEJ-UHFFFAOYSA-N 0.000 claims description 3
- 239000000741 silica gel Substances 0.000 claims description 3
- 229910002027 silica gel Inorganic materials 0.000 claims description 3
- 238000002347 injection Methods 0.000 abstract description 11
- 239000007924 injection Substances 0.000 abstract description 11
- 206010022046 Injection site anaesthesia Diseases 0.000 abstract description 2
- 239000000428 dust Substances 0.000 abstract description 2
- 238000003780 insertion Methods 0.000 description 4
- 230000037431 insertion Effects 0.000 description 4
- 238000010586 diagram Methods 0.000 description 3
- 230000007306 turnover Effects 0.000 description 2
- 230000009286 beneficial effect Effects 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 230000008569 process Effects 0.000 description 1
- 230000001568 sexual effect Effects 0.000 description 1
- 239000000243 solution Substances 0.000 description 1
Images


Classifications
-
- G—PHYSICS
- G09—EDUCATION; CRYPTOGRAPHY; DISPLAY; ADVERTISING; SEALS
- G09B—EDUCATIONAL OR DEMONSTRATION APPLIANCES; APPLIANCES FOR TEACHING, OR COMMUNICATING WITH, THE BLIND, DEAF OR MUTE; MODELS; PLANETARIA; GLOBES; MAPS; DIAGRAMS
- G09B23/00—Models for scientific, medical, or mathematical purposes, e.g. full-sized devices for demonstration purposes
- G09B23/28—Models for scientific, medical, or mathematical purposes, e.g. full-sized devices for demonstration purposes for medicine
- G09B23/285—Models for scientific, medical, or mathematical purposes, e.g. full-sized devices for demonstration purposes for medicine for injections, endoscopy, bronchoscopy, sigmoidscopy, insertion of contraceptive devices or enemas
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01B—MEASURING LENGTH, THICKNESS OR SIMILAR LINEAR DIMENSIONS; MEASURING ANGLES; MEASURING AREAS; MEASURING IRREGULARITIES OF SURFACES OR CONTOURS
- G01B21/00—Measuring arrangements or details thereof, where the measuring technique is not covered by the other groups of this subclass, unspecified or not relevant
- G01B21/02—Measuring arrangements or details thereof, where the measuring technique is not covered by the other groups of this subclass, unspecified or not relevant for measuring length, width, or thickness
- G01B21/06—Measuring arrangements or details thereof, where the measuring technique is not covered by the other groups of this subclass, unspecified or not relevant for measuring length, width, or thickness specially adapted for measuring length or width of objects while moving
Landscapes
- Engineering & Computer Science (AREA)
- General Physics & Mathematics (AREA)
- Physics & Mathematics (AREA)
- Health & Medical Sciences (AREA)
- Computational Mathematics (AREA)
- Mathematical Optimization (AREA)
- Medical Informatics (AREA)
- Medicinal Chemistry (AREA)
- Chemical & Material Sciences (AREA)
- Algebra (AREA)
- Radiology & Medical Imaging (AREA)
- Pulmonology (AREA)
- Mathematical Analysis (AREA)
- General Health & Medical Sciences (AREA)
- Mathematical Physics (AREA)
- Pure & Applied Mathematics (AREA)
- Business, Economics & Management (AREA)
- Educational Administration (AREA)
- Educational Technology (AREA)
- Theoretical Computer Science (AREA)
- Instructional Devices (AREA)
Abstract
本发明公开了麻醉技术操作训练模型,包括控制机构、训练机构、翻转机构和收纳箱,收纳箱的两端设有翻转机构,翻转机构的顶部固定安装有训练机构,收纳箱的一端固定安装有控制机构,翻转机构由固定块、三号电动伸缩杆、万向轮、一号收纳槽、一号电动伸缩杆、二号收纳槽、二号电动伸缩杆、二号轴套、一号轴套、转轴、传动盒、翻转电机、主动齿轮、防护外壳和从动齿轮组成。通过在人型模型各麻醉注射部位安装了压力传感器,因此对麻醉技术注射时的位置进行反复练习,提高其注射时的准确度,并且通过设置了翻转机构,在不用时可以将训练机构进行收纳,避免其落有灰尘,并且可将其作为讲台或者试验台使用,提高了其实用性。
The invention discloses an anesthesia technique operation training model, which includes a control mechanism, a training mechanism, a turning mechanism and a storage box. The two ends of the storage box are provided with a turning mechanism, the top of the turning mechanism is fixedly installed with a training mechanism, and one end of the storage box is fixedly installed with a training mechanism. The control mechanism, the turning mechanism consists of a fixed block, No. 3 electric telescopic rod, universal wheel, No. 1 storage slot, No. 1 electric telescopic rod, No. 2 storage slot, No. 2 electric telescopic rod, No. 2 shaft sleeve, No. 1 shaft sleeve. , rotating shaft, transmission box, turning motor, driving gear, protective casing and driven gear. The pressure sensor is installed at each anesthesia injection site of the humanoid model, so the position of the anesthesia technique can be repeatedly practiced to improve the accuracy of the injection, and the reversing mechanism is provided, so that the training mechanism can be stored when not in use. , to avoid dust, and it can be used as a lectern or a test bench, which improves its practicability.
Description
技术领域:Technical field:
本发明属于麻醉训练技术领域,特别涉及麻醉技术操作训练模型。The invention belongs to the technical field of anesthesia training, and particularly relates to an operation training model of anesthesia technology.
背景技术:Background technique:
在麻醉技术的训练过程中,注射训练是十分常见和重要的训练之一。现有的麻醉注射训练时大多是通过训练模型进行注射,现有的训练模型结构死板,功能单一,无法对注射位置和针头伸入长度进行检测和判断,无法对训练结果进行提醒,无法提高其注射时的准确度,无法提高其实用性。In the training process of anesthesia technique, injection training is one of the most common and important trainings. Most of the existing anesthesia injection training is carried out through the training model. The existing training model has a rigid structure and a single function. It cannot detect and judge the injection position and the length of the needle insertion. The accuracy at the time of injection cannot improve its practicality.
发明内容:Invention content:
本发明的目的就在于为了解决上述问题而提供麻醉技术操作训练模型,解决了现有的设备所存在的缺点。The purpose of the present invention is to provide an anesthesia technique operation training model in order to solve the above problems, and to solve the shortcomings of the existing equipment.
为了解决上述问题,本发明提供了麻醉技术操作训练模型技术方案:In order to solve the above problems, the present invention provides a technical scheme of anesthesia technique operation training model:
麻醉技术操作训练模型,包括控制机构、训练机构、翻转机构和收纳箱,所述收纳箱的两端设有翻转机构,所述翻转机构的顶部固定安装有训练机构,所述收纳箱的一端固定安装有控制机构,所述翻转机构由固定块、三号电动伸缩杆、万向轮、一号收纳槽、一号电动伸缩杆、二号收纳槽、二号电动伸缩杆、二号轴套、一号轴套、转轴、传动盒、翻转电机、主动齿轮、防护外壳和从动齿轮组成,所述收纳箱的一端固定连接有一号收纳槽,所述一号收纳槽的内部固定连接有一号电动伸缩杆,所述一号电动伸缩杆的顶部固定安装有传动盒,所述传动盒的内部固定安装有翻转电机,所述翻转电机的输出端贯穿传动盒且固定连接有主动齿轮,所述传动盒的顶部固定连接有一号轴套,所述一号轴套的内部转动连接有转轴,所述转轴的一端且位于主动齿轮的上方固定连接有从动齿轮,所述从动齿轮与主动齿轮啮合连接,所述收纳箱远离一号收纳槽的一侧固定连接有二号收纳槽,所述二号收纳槽的内部固定安装有二号电动伸缩杆,所述二号电动伸缩杆的顶部固定连接有二号轴套。Anesthesia technique operation training model, including a control mechanism, a training mechanism, a turning mechanism and a storage box, the two ends of the storage box are provided with a turnover mechanism, the top of the turnover mechanism is fixedly installed with a training mechanism, and one end of the storage box is fixed A control mechanism is installed, and the turning mechanism consists of a fixed block, No. 3 electric telescopic rod, universal wheel, No. 1 storage slot, No. 1 electric telescopic rod, No. 2 storage slot, No. 2 electric telescopic rod, No. 2 shaft sleeve, The No. 1 shaft sleeve, the rotating shaft, the transmission box, the turning motor, the driving gear, the protective casing and the driven gear are composed. One end of the storage box is fixedly connected with a No. 1 storage slot, and the inside of the No. 1 storage slot is fixedly connected with a No. 1 electric motor. A telescopic rod, a transmission box is fixedly installed on the top of the No. 1 electric telescopic rod, a turning motor is fixedly installed inside the transmission box, and the output end of the turning motor runs through the transmission box and is fixedly connected with a driving gear. The top of the box is fixedly connected with a No. 1 bushing, the inside of the No. 1 bushing is rotatably connected with a rotating shaft, and one end of the rotating shaft is fixedly connected with a driven gear above the driving gear, and the driven gear is meshed with the driving gear. Connection, the side of the storage box away from the storage slot No. 1 is fixedly connected with the storage slot No. 2, the inside of the storage slot No. 2 is fixedly installed with a No. 2 electric telescopic rod, and the top of the No. 2 electric telescopic rod is fixedly connected There is a No. 2 bushing.
作为优选,所述控制机构由存放柜、操作台、控制面板、显示屏、报警器和警示灯组成,所述一号收纳槽的一侧固定安装有操作台,所述操作台的底部固定安装有存放柜,所述操作台的一侧固定安装有控制面板,所述操作台的顶部转动连接有显示屏,所述显示屏的顶部固定安装有警示灯,所述显示屏的一侧固定安装有报警器。Preferably, the control mechanism is composed of a storage cabinet, an operating table, a control panel, a display screen, an alarm and a warning light, the operating table is fixedly installed on one side of the No. 1 storage slot, and the bottom of the operating table is fixedly installed There is a storage cabinet, a control panel is fixedly installed on one side of the operating table, a display screen is rotatably connected to the top of the operating table, a warning light is fixedly installed on the top of the display screen, and one side of the display screen is fixedly installed There are alarms.
作为优选,所述训练机构由翻板、训练模型和压力传感器组成,所述翻板的两端均与转轴固定连接,所述翻板的一侧固定安装有训练模型,所述训练模型的内部固定安装有若干个压力传感器。Preferably, the training mechanism is composed of a flap, a training model and a pressure sensor, both ends of the flap are fixedly connected to the rotating shaft, a training model is fixedly installed on one side of the flap, and the interior of the training model is Several pressure sensors are fixedly installed.
作为优选,所述收纳箱内部的四角均固定连接有固定块,所述固定块的底部均固定连接有三号电动伸缩杆,所述三号电动伸缩杆的输出端从收纳箱的底部穿出且固定连接有万向轮。Preferably, four corners inside the storage box are fixedly connected with fixing blocks, and the bottom of the fixing blocks is fixedly connected with a No. 3 electric telescopic rod, and the output end of the No. 3 electric telescopic rod passes through the bottom of the storage box and is The fixed connection has a universal wheel.
作为优选,所述传动盒的一端固定安装有防护外壳,所述从动齿轮与主动齿轮均位于防护外壳的内部。Preferably, a protective casing is fixedly mounted on one end of the transmission box, and both the driven gear and the driving gear are located inside the protective casing.
作为优选,所述三号电动伸缩杆、一号电动伸缩杆、二号电动伸缩杆、翻转电机、显示屏、报警器、警示灯和压力传感器均与控制面板电性连接。Preferably, the No. 3 electric telescopic rod, No. 1 electric telescopic rod, No. 2 electric telescopic rod, turning motor, display screen, alarm, warning light and pressure sensor are all electrically connected to the control panel.
作为优选,所述训练模型为人型结构,且所述训练模型由硅胶制成。Preferably, the training model is a humanoid structure, and the training model is made of silica gel.
作为优选,所述翻板的宽度与收纳箱内壁的宽度相同。Preferably, the width of the flap is the same as the width of the inner wall of the storage box.
本发明的有益效果:通过在人型模型各麻醉注射部位安装了压力传感器,当注射位置和针头伸入长度达标时。注射器的针头会触碰到对应位置的压力传感器,此时警示灯和报警器会发出警示.当注射位置和针头伸入长度不达标时,注射器的针头不会触碰到对应位置的压力传感器,此时警示灯和报警器不会发出警示。因此对麻醉技术注射时的位置进行反复练习,提高其注射时的准确度,并且通过设置了翻转机构。在不用时可以将训练机构进行收纳,避免其落有灰尘并且可将其作为讲台或者试验台使用,提高了其实用性。The beneficial effects of the present invention are as follows: by installing a pressure sensor on each anesthesia injection site of the humanoid model, when the injection position and the needle insertion length reach the standard. The needle of the syringe will touch the pressure sensor at the corresponding position, and the warning light and alarm will issue a warning. When the injection position and the length of the needle are not up to standard, the needle of the syringe will not touch the pressure sensor at the corresponding position. At this time, the warning light and alarm will not sound. Therefore, the position of the anesthesia technique during injection is repeatedly practiced to improve the accuracy of the injection, and a turning mechanism is set. When not in use, the training mechanism can be stored to avoid dust and can be used as a lectern or a test bench, which improves its practicability.
附图说明:Description of drawings:
为了易于说明,本发明由下述的具体实施及附图作以详细描述。For ease of description, the present invention is described in detail by the following specific implementations and accompanying drawings.
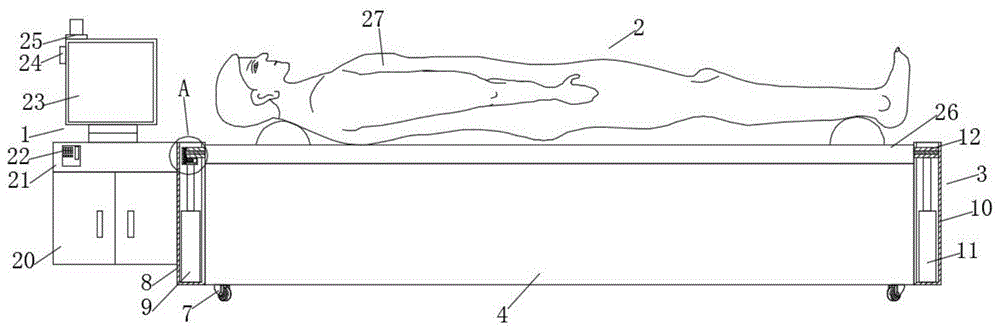
图1为本发明的结构示意图;Fig. 1 is the structural representation of the present invention;
图2为本发明的A处放大结构示意图;Fig. 2 is the enlarged structure schematic diagram of A place of the present invention;
图3为本发明的翻板翻转后结构示意图;3 is a schematic structural diagram of the flip plate of the present invention after being turned over;
图4为本发明的训练模型内部结构示意图;4 is a schematic diagram of the internal structure of the training model of the present invention;
图5为本发明的俯视图。FIG. 5 is a top view of the present invention.
图中:1、控制机构;2、训练机构;3、翻转机构;4、收纳箱;5、固定块;6、三号电动伸缩杆;7、万向轮;8、一号收纳槽;9、一号电动伸缩杆;10、二号收纳槽;11、二号电动伸缩杆;12、二号轴套;13、一号轴套;14、转轴;15、传动盒;16、翻转电机;17、主动齿轮;18、防护外壳;19、从动齿轮;20、存放柜;21、操作台;22、控制面板;23、显示屏;24、报警器;25、警示灯;26、翻板;27、训练模型;28、压力传感器。In the figure: 1. Control mechanism; 2. Training mechanism; 3. Turning mechanism; 4. Storage box; 5. Fixed block; 6. Electric telescopic rod No. 3; 7. Universal wheel; 8. Storage slot No. 1; , No. 1 electric telescopic rod; 10, No. 2 storage slot; 11, No. 2 electric telescopic rod; 12, No. 2 bushing; 13, No. 1 bushing; 17. Driving gear; 18. Protective casing; 19. Driven gear; 20. Storage cabinet; 21. Operating console; 22. Control panel; 23. Display screen; 24. Alarm; 25. Warning light; 26. Flip plate ; 27. Training model; 28. Pressure sensor.
具体实施方式:Detailed ways:
如图1-5所示,本具体实施方式采用以下技术方案:麻醉技术操作训练模型,包括控制机构1、训练机构2、翻转机构3和收纳箱4,所述收纳箱4的两端设有翻转机构3,所述翻转机构3的顶部固定安装有训练机构2,所述收纳箱4的一端固定安装有控制机构1,所述翻转机构3由固定块5、三号电动伸缩杆6、万向轮7、一号收纳槽8、一号电动伸缩杆9、二号收纳槽10、二号电动伸缩杆11、二号轴套12、一号轴套13、转轴14、传动盒15、翻转电机16、主动齿轮17、防护外壳18和从动齿轮19组成,所述收纳箱4的一端固定连接有一号收纳槽8,所述一号收纳槽8的内部固定连接有一号电动伸缩杆9,所述一号电动伸缩杆9的顶部固定安装有传动盒15,所述传动盒15的内部固定安装有翻转电机16,所述翻转电机16的输出端贯穿传动盒15且固定连接有主动齿轮17,所述传动盒15的顶部固定连接有一号轴套13,所述一号轴套13的内部转动连接有转轴14,所述转轴14的一端且位于主动齿轮17的上方固定连接有从动齿轮19,所述从动齿轮19与主动齿轮17啮合连接,所述收纳箱4远离一号收纳槽8的一侧固定连接有二号收纳槽10,所述二号收纳槽10的内部固定安装有二号电动伸缩杆11,所述二号电动伸缩杆11的顶部固定连接有二号轴套12。As shown in Figures 1-5, this specific embodiment adopts the following technical solutions: an anesthesia technology operation training model, including a
其中,所述控制机构1由存放柜20、操作台21、控制面板22、显示屏23、报警器24和警示灯25组成,所述一号收纳槽8的一侧固定安装有操作台21,所述操作台21的底部固定安装有存放柜20,所述操作台21的一侧固定安装有控制面板22,所述操作台21的顶部转动连接有显示屏23,所述显示屏23的顶部固定安装有警示灯25,所述显示屏23的一侧固定安装有报警器24。Wherein, the
其中,所述训练机构2由翻板26、训练模型27和压力传感器28组成,所述翻板26的两端均与转轴14固定连接,所述翻板26的一侧固定安装有训练模型27,所述训练模型27的内部固定安装有若干个压力传感器28,压力传感器28的型号为FSR402。The training mechanism 2 is composed of a
其中,所述收纳箱4内部的四角均固定连接有固定块5,所述固定块5的底部均固定连接有三号电动伸缩杆6,所述三号电动伸缩杆6的输出端从收纳箱4的底部穿出且固定连接有万向轮7,便于移动和调节高度。Wherein, the four corners inside the
其中,所述传动盒15的一端固定安装有防护外壳18,所述从动齿轮19与主动齿轮17均位于防护外壳18的内部,防止出现夹伤等事故。One end of the
其中,所述三号电动伸缩杆6、一号电动伸缩杆9、二号电动伸缩杆11、翻转电机16、显示屏23、报警器24、警示灯25和压力传感器28均与控制面板22电性连接,便于控制其正常工作。Among them, the No. 3 electric
其中,所述训练模型27为人型结构,且所述训练模型27由硅胶制成,便于训练使用。Wherein, the
其中,所述翻板26的宽度与收纳箱4内壁的宽度相同,便于将翻板26收入收纳箱4内。Wherein, the width of the
具体的:麻醉技术操作训练模型,使用时,通过万向轮7将该装置移动到指定位置,然后根据身高和需要的高度。通过控制面板22控制三号电动伸缩杆6的伸缩,通过三号电动伸缩杆6的伸缩调节收纳箱4的高度,调节完成后。通过控制面板22控制一号电动伸缩杆9和二号电动伸缩杆11同时升起,一号电动伸缩杆9和二号电动伸缩杆11将翻板26推到顶部,然后控制翻转电机16转动,翻转电机16通过主动齿轮17带动防护外壳18转动。防护外壳18通过转轴14带动翻板26转动,以此将翻板26装有训练模型27的一面朝上然后控制一号电动伸缩杆9和二号电动伸缩杆11回缩,将翻板26回缩进收纳箱4内。此时,麻醉护士人员可以通过注射器对各麻醉部位进行注射,因各麻醉部位的内部均安装有压力传感器28,当注射位置和针头伸入长度达标时。注射器的针头会触碰到对应位置的压力传感器28,压力传感器28检测到压力信号时将信号传递给控制面板22,控制面板22控制警示灯25和报警器24发出警示。当注射位置和针头伸入长度不达标时,注射器的针头不会触碰到对应位置的压力传感器28,压力传感器28检测不到压力信号,警示灯25和报警器24不会发出警示。当不用时,通过控制一号电动伸缩杆9和二号电动伸缩杆11同时升起。一号电动伸缩杆9和二号电动伸缩杆11将翻板26推到顶部,然后控制翻转电机16转动,翻转电机16通过主动齿轮17带动防护外壳18转动,防护外壳18通过转轴14带动翻板26转动,将训练模型27朝下。然后通过一号电动伸缩杆9和二号电动伸缩杆11将翻板26带入收纳箱4内,可以起到防尘作用并且可以将翻板26做桌子使用。Specifically: the anesthesia technical operation training model, when in use, move the device to the designated position through the universal wheel 7, and then according to the height and the required height. The
以上显示和描述了本发明的基本原理和主要特征和本发明的优点,本行业的技术人员应该了解,本发明不受上述实施例的限制,上述实施例和说明书中描述的只是说明本发明的原理,在不脱离本发明精神和范围的前提下,本发明还会有各种变化和改进,这些变化和改进都落入要求保护的本发明范围内,本发明要求保护范围由所附的权利要求书及其等效物界定。The basic principles, main features and advantages of the present invention are shown and described above. Those skilled in the art should understand that the present invention is not limited by the above-mentioned embodiments, and the descriptions in the above-mentioned embodiments and the description are only for illustrating the present invention. principle, without departing from the spirit and scope of the present invention, the present invention will also have various changes and improvements, these changes and improvements all fall within the scope of the claimed invention, and the claimed scope of the present invention is determined by the appended rights Requirements and their equivalents are defined.
Claims (8)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201910739451.XA CN111292598A (en) | 2019-08-12 | 2019-08-12 | Anesthesia technology operation training model |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201910739451.XA CN111292598A (en) | 2019-08-12 | 2019-08-12 | Anesthesia technology operation training model |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN111292598A true CN111292598A (en) | 2020-06-16 |
Family
ID=71023296
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201910739451.XA Pending CN111292598A (en) | 2019-08-12 | 2019-08-12 | Anesthesia technology operation training model |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN111292598A (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117409649A (en) * | 2023-12-15 | 2024-01-16 | 吉林大学 | Bronchoscope training model |
| CN117558191A (en) * | 2024-01-11 | 2024-02-13 | 吉林大学 | A kind of nasogastric feeding operation demonstration device |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002132138A (en) * | 2000-10-25 | 2002-05-09 | Nippon Medico Kk | Epidural puncture simulator |
| TW201207785A (en) * | 2010-08-13 | 2012-02-16 | Eped Inc | Dental anesthesia injection training simulation system and evaluation method thereof |
| CN103426352A (en) * | 2013-07-26 | 2013-12-04 | 高颖 | Multifunctional acupuncture three-dimensional teaching model and teaching system thereof |
| UA93678U (en) * | 2014-05-12 | 2014-10-10 | Вінницький Національний Медичний Університет Ім. М.І. Пирогова | METHOD for ASSESSMENT of effect of peridural anesthesia / analgesia ON improvement of bowels microcirculation in EXPERIMENT |
| CN107067925A (en) * | 2017-05-24 | 2017-08-18 | 贵阳中医学院 | A massage training device and method |
| CN110009982A (en) * | 2019-04-22 | 2019-07-12 | 山东中医药大学 | A simulation training evaluation system for massage manipulation |
-
2019
- 2019-08-12 CN CN201910739451.XA patent/CN111292598A/en active Pending
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002132138A (en) * | 2000-10-25 | 2002-05-09 | Nippon Medico Kk | Epidural puncture simulator |
| TW201207785A (en) * | 2010-08-13 | 2012-02-16 | Eped Inc | Dental anesthesia injection training simulation system and evaluation method thereof |
| CN103426352A (en) * | 2013-07-26 | 2013-12-04 | 高颖 | Multifunctional acupuncture three-dimensional teaching model and teaching system thereof |
| UA93678U (en) * | 2014-05-12 | 2014-10-10 | Вінницький Національний Медичний Університет Ім. М.І. Пирогова | METHOD for ASSESSMENT of effect of peridural anesthesia / analgesia ON improvement of bowels microcirculation in EXPERIMENT |
| CN107067925A (en) * | 2017-05-24 | 2017-08-18 | 贵阳中医学院 | A massage training device and method |
| CN110009982A (en) * | 2019-04-22 | 2019-07-12 | 山东中医药大学 | A simulation training evaluation system for massage manipulation |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117409649A (en) * | 2023-12-15 | 2024-01-16 | 吉林大学 | Bronchoscope training model |
| CN117409649B (en) * | 2023-12-15 | 2024-02-27 | 吉林大学 | Bronchoscopy training model |
| CN117558191A (en) * | 2024-01-11 | 2024-02-13 | 吉林大学 | A kind of nasogastric feeding operation demonstration device |
| CN117558191B (en) * | 2024-01-11 | 2024-03-22 | 吉林大学 | A kind of nasogastric feeding operation demonstration device |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN206348956U (en) | A kind of Double video frequency interactive teaching exhibiting instrument | |
| CN209485361U (en) | A kind of road construction plotting board with dust reduction capability | |
| CN106978330A (en) | A kind of microbiological incubator | |
| CN112593734A (en) | Intelligent industrial touch screen | |
| CN208875548U (en) | A kind of Electronics and Information Engineering laboratory computer tables | |
| CN112419843B (en) | Economic management is with multi-functional teaching presentation device | |
| CN111366302B (en) | Power Safety IoT SF6 Gas Leak Detector | |
| CN220481737U (en) | An anti-overturning inspection robot | |
| CN108681368B (en) | A convenient fixed-use electronic information automation demonstration display stand | |
| CN206194219U (en) | A mechanical link motion principle demonstration teaching aid for physical teaching | |
| CN211651959U (en) | Power Safety IoT SF6 Gas Leak Detector | |
| CN207974163U (en) | A kind of device of the deep foundation pit slope deformation of monitoring at any time | |
| CN209838396U (en) | Ground source heat pump well depth detection device | |
| CN208121349U (en) | A kind of computer embroidering machine intelligence control system based on fault diagnosis | |
| CN217262214U (en) | A kind of dechlorination ash warehouse storage metering detection device | |
| CN209364673U (en) | An automatic test equipment for the head of an electric vehicle intelligent robot | |
| CN221613381U (en) | Hand-held household alarm | |
| CN112504536B (en) | An agricultural tractor working part torque measuring device | |
| CN219624731U (en) | Flatness detection device for liquid crystal display screen | |
| CN222748912U (en) | Safety protection device for touch control integrated machine | |
| CN221858148U (en) | Control instrument fixing device | |
| CN218098272U (en) | Mechanical arm for testing durability of mouse | |
| CN209247063U (en) | A kind of temperature and humidity sensing device that can be used in the presence of a harsh environment | |
| CN218514688U (en) | Single pillar intelligent monitoring control device convenient to get and put | |
| CN217830590U (en) | A 3D detection automatic dispensing machine |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PB01 | Publication | ||
| PB01 | Publication | ||
| SE01 | Entry into force of request for substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| RJ01 | Rejection of invention patent application after publication | ||
| RJ01 | Rejection of invention patent application after publication |
Application publication date: 20200616 |