WO2024218878A1 - 異常判定装置、異常判定システム、および異常判定方法 - Google Patents
異常判定装置、異常判定システム、および異常判定方法 Download PDFInfo
- Publication number
- WO2024218878A1 WO2024218878A1 PCT/JP2023/015523 JP2023015523W WO2024218878A1 WO 2024218878 A1 WO2024218878 A1 WO 2024218878A1 JP 2023015523 W JP2023015523 W JP 2023015523W WO 2024218878 A1 WO2024218878 A1 WO 2024218878A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- correction value
- past
- setting information
- current
- unit
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B19/00—Program-control systems
- G05B19/02—Program-control systems electric
- G05B19/18—Numerical control [NC], i.e. automatically operating machines, in particular machine tools, e.g. in a manufacturing environment, so as to execute positioning, movement or co-ordinated operations by means of program data in numerical form
- G05B19/406—Numerical control [NC], i.e. automatically operating machines, in particular machine tools, e.g. in a manufacturing environment, so as to execute positioning, movement or co-ordinated operations by means of program data in numerical form characterised by monitoring or safety
Definitions
- This disclosure relates to an abnormality determination device, an abnormality determination system, and an abnormality determination method that perform abnormality determination of correction values set in a machine tool.
- Machine tools process the workpiece while correcting the tool position, etc.
- Machine tools perform processing while correcting the tool position based on the amount of tool position correction input by the operator. For this reason, it is desirable for the amount of correction input by the operator to be an appropriate amount of correction.
- the machine tool control device described in Patent Document 1 corrects the amount of tool movement according to a correction amount input by an operator, and stores the input correction amount, correction timing, and operator ID as historical data. Then, when a stored operator ID is selected, the machine tool control device automatically corrects the amount of tool movement according to the correction amount and correction timing corresponding to this operator ID, and performs machining.
- Patent Document 1 predicts and automatically corrects the correction value using an approximation formula, which creates a problem in that there is a high possibility that an inappropriate correction value predicted by the approximation formula will be adopted, and the machining will be performed with the automatic correction using the inappropriate correction value.
- the present disclosure has been made in consideration of the above, and aims to provide an abnormality determination device that can perform processing while reducing the possibility of correction with an inappropriate correction value.
- the abnormality determination device disclosed herein includes an operator input unit that receives from an operator a correction value that is set for the operation of a tool defined in a machining program used by the machine tool as a current correction value, and a setting information comparison unit that compares the current correction value set in the machine tool with a past correction value that was set for the operation of the tool when machining was performed appropriately in the past.
- the abnormality determination device disclosed herein also includes an abnormality detection unit that detects an abnormality in the current correction value based on a correction value difference, which is the difference between the current correction value and the past correction value, and a display control unit that causes a display device to display information indicating that the current correction value is inappropriate when the abnormality detection unit detects an abnormality.
- the abnormality determination device disclosed herein has the effect of reducing the possibility of correction with an inappropriate correction value and allowing processing to be performed.
- Embodiment 1 is a diagram showing a configuration of an abnormality determination system according to an embodiment.
- Abnormality determination system 1 includes a machine tool 10 and a server 30.
- Abnormality determination system 1 is a system (fault detection system) that determines a correction value set for a tool or the like before machine tool 10 starts machining, and notifies an operator of at least one of an appropriate correction value candidate (reset candidate value) and an alarm if a setting error occurs.
- the machine tool 10 has an operator input unit 11, a machining program operation unit 12, a machining inference unit 13, a setting information storage unit 14, a learned model storage unit 21, a display control unit 22, and a display device 23.
- the server 30 has a setting information acquisition unit 31, a setting information storage unit 32, a setting information comparison unit 33, an anomaly detection unit 34, a data acquisition unit 41, and a model generation unit 42.
- the data acquisition unit 41 and the model generation unit 42 are learning devices.
- At least one of the trained model storage unit 21 and the display control unit 22 may be disposed outside the machine tool 10. At least one of the trained model storage unit 21 and the display control unit 22 may be disposed, for example, within the server 30.
- At least one of the data acquisition unit 41 and the model generation unit 42 may be located outside the server 30. At least one of the data acquisition unit 41 and the model generation unit 42 may be located, for example, within the machine tool 10.
- the operator input unit 11 accepts data input by an operator.
- the operator input unit 11 accepts, for example, processing setting information, difference thresholds, and the like input by the operator.
- the processing setting information input by the operator includes processing program information, correction information, and tool number (tool identification information).
- the information on the machining program is, for example, a program number (program identification information).
- the program number is information that identifies the machining program.
- FIG. 1 shows a case where the operator input unit 11 has received a program number as information on the machining program.
- the program number may be any information that identifies a machining program for machining a workpiece.
- the correction information is information in which a correction number (correction identification information) is associated with a correction value.
- the correction value is, for example, a value for correcting the operation of a tool, which is set for the operation of the tool defined in the machining program.
- the correction number is information for identifying the correction item corresponding to the correction value.
- the correction number may be any information that identifies the correction item corresponding to the correction value. For example, if the correction item is the amount of movement of the tool, "001" is set as the correction number. In this case, in the correction information, "001" is associated with the correction value for the amount of movement of the tool defined in the machining program.
- the tool number is information for identifying a tool.
- the tool number may be any information that identifies a tool.
- the difference threshold is a threshold for the difference between an appropriate correction value used in the past (hereinafter, sometimes referred to as a past correction value) and the correction value currently being set (hereinafter, sometimes referred to as a current correction value).
- the setting information may include information other than the program number as information about the machining program.
- the machining program information may include, for example, a timestamp, shape information, machining command information (e.g., M code, G code), etc.
- the timestamp is information indicating the date and time when the machining program was created
- the shape information is information indicating the shape of the product to be produced by the machining program.
- the information included in the machining program information is not limited to the information described above.
- the machining program information may include at least one of the program number, timestamp, and shape information.
- the setting information includes information on the correction value and the machining program.
- the setting information may also include at least one of a correction number and a tool number.
- the machine tool 10 uses various machining programs and various setting information to machine various workpieces. In this embodiment, a case will be described in which the setting information input by the operator is a program number, correction information, and tool number.
- the operator input unit 11 sends the program number, the correction information, and the tool number to the machining program operation unit 12. In other words, the operator input unit 11 sends the setting information for the machining process to the machining program operation unit 12.
- the operator input unit 11 also stores the difference threshold in the setting information storage unit 14.
- the operator input unit 11 also sends the difference threshold to the anomaly detection unit 34 of the server 30. Note that the connection line connecting the operator input unit 11 and the anomaly detection unit 34 is not shown in FIG. 1.
- the machining program operation unit 12 accepts setting information including a program number, compensation information, and tool number from the operator input unit 11.
- the machining program operation unit 12 sends setting information associating the program number, compensation information, and tool number to the machining inference unit 13.
- the machining program operation unit 12 also sends setting information associating the program number, compensation information, and tool number to the setting information comparison unit 33 of the server 30.
- the setting information sent by the machining program operation unit 12 to the machining inference unit 13 and the setting information comparison unit 33 is the setting information currently set in the machine tool 10 (hereinafter sometimes referred to as current setting information).
- the trained model storage unit 21 stores the trained model generated by the model generation unit 42 of the server 30.
- the trained model is a function for inferring whether the processing performed using the current correction value (hereinafter, may be referred to as the current processing) is the same as a normal processing performed using a past correction value (hereinafter, may be referred to as the past processing).
- the trained model is used to determine whether the current processing and the past processing are the same processing.
- the same machining process is one that is executed using the same machining program and the same tools in the past and the current process, and the difference between the past correction value used in the normal machining process executed in the past and the current correction value is equal to or less than the difference threshold value.
- the processing inference unit 13 receives current setting information from the processing program operation unit 12 and reads out the learned model from the learned model storage unit 21. By inputting the current setting information into the learned model, the processing inference unit 13 infers whether the current processing to be executed and the past processing are the same processing.
- the processing inference unit 13 determines that the current processing and the past processing are not the same processing, it sends this determination result to the display control unit 22. Also, if the processing inference unit 13 determines that the current processing and the past processing are the same processing, it stores the current setting information in the setting information storage unit 14. That is, the processing inference unit 13 stores the program number, the correction information, and the tool number in the setting information storage unit 14.
- the setting information storage unit 14 stores the processing success/failure information, the current setting information sent from the processing inference unit 13, and the difference threshold value sent from the operator input unit 11.
- the processing success/failure information is information that indicates whether the currently executed processing was normal or abnormal.
- the processing success/failure information is determined based on factors such as the shape of the finished product produced by the current processing.
- the display control unit 22 When the display control unit 22 receives information from the processing inference unit 13 indicating that the current processing process and the past processing process are not the same processing process, it causes the display device 23 to display information indicating that the current processing process and the past processing process cannot be compared.
- the display control unit 22 When the display control unit 22 receives information from the server 30 indicating that the setting information (correction value) is inappropriate, the display control unit 22 causes the display device 23 to display an alarm indicating that the correction value is inappropriate. When the display control unit 22 receives a candidate correction value (reset candidate value) included in the setting information from the server 30, the display control unit 22 causes the display device 23 to display the reset candidate value. When the display control unit 22 receives information from the server 30 indicating that the correction value is appropriate, the display control unit 22 causes the display device 23 to display information indicating that the correction value is appropriate.
- the setting information acquisition unit 31 reads the current setting information and the difference threshold from the setting information storage unit 14 and stores them in the setting information accumulation unit 32. Furthermore, when the setting information storage unit 14 stores the processing success/failure information, the setting information acquisition unit 31 reads the processing success/failure information from the setting information storage unit 14. That is, after the current processing is completed, the setting information acquisition unit 31 reads the processing success/failure information from the setting information storage unit 14. The setting information acquisition unit 31 associates the read processing success/failure information with the current setting information and the difference threshold already stored in the setting information storage unit 14, and stores it in the setting information accumulation unit 32. Note that the setting information storage unit 14 may transmit the processing success/failure information, the current setting information, and the difference threshold to the setting information acquisition unit 31.
- the setting information accumulation unit 32 has a collection database that stores collected data, and in this collection database, it stores processing success/failure information, setting information, and a difference threshold in association with each other.
- the setting information stored by the setting information accumulation unit 32 is past setting information. In this way, the setting information is current setting information before processing is completed, and becomes past setting information when it is associated with processing success/failure information after processing is completed. Note that the past setting information does not need to include the difference threshold.
- the setting information comparison unit 33 receives current setting information in which a program number, correction information, and tool number are associated with each other from the machining program operation unit 12.
- the setting information comparison unit 33 may read out the current setting information from the setting information storage unit 14, or may receive the current setting information from the setting information storage unit 14.
- the setting information comparison unit 33 also reads out past setting information having the same program number and tool number as the program number and tool number included in the current setting information from the setting information accumulation unit 32. Note that the setting information comparison unit 33 may read out multiple pieces of past setting information from the setting information accumulation unit 32.
- the setting information comparison unit 33 compares the current setting information with the past setting information. Specifically, the setting information comparison unit 33 compares the correction value of the correction information included in the current setting information with the correction value of the correction information included in the past setting information. If the setting information comparison unit 33 reads out multiple past correction values, it compares the average value of the multiple past correction values with the current correction value. The setting information comparison unit 33 may also compare the most frequent or median value of the multiple past correction values with the current correction value.
- the setting information comparison unit 33 calculates the difference between the correction value of the correction information included in the current setting information and the correction value of the correction information included in the past setting information (hereinafter, sometimes referred to as the correction value difference), and sends the correction value difference to the anomaly detection unit 34.
- the abnormality detection unit 34 judges whether the current setting information (correction value) is an appropriate value based on the correction value difference sent from the setting information comparison unit 33 and the difference threshold value sent from the operator input unit 11. If the correction value difference is equal to or greater than the difference threshold value, the abnormality detection unit 34 judges that the current correction value is inappropriate, and if the correction value difference is smaller than the difference threshold value, it judges that the current correction value is appropriate.
- the abnormality detection unit 34 determines that the current correction value is appropriate, it sends information indicating that the current correction value is appropriate to the display control unit 22. If the abnormality detection unit 34 determines that the current correction value is inappropriate, it sends information (alarm) indicating that the current correction value is inappropriate to the display control unit 22.
- the abnormality detection unit 34 determines that the current correction value is inappropriate, it acquires from the setting information comparison unit 33 the past correction value used for comparison by the setting information comparison unit 33. That is, the abnormality detection unit 34 acquires from the setting information comparison unit 33, among the past correction values, the past correction value that has been compared with the current correction value that has been determined to be inappropriate.
- the abnormality detection unit 34 determines a reset candidate value that is a candidate for an appropriate correction value based on the acquired past correction value. For example, the abnormality detection unit 34 determines the average value of the acquired past correction values as the reset candidate value. That is, the abnormality detection unit 34 determines the average value of the past correction values that have been compared with the current correction value that has been determined to be inappropriate as the reset candidate value.
- the abnormality detection unit 34 sends the determined reset candidate value to the display control unit 22.
- the data acquisition unit 41 acquires setting information including information on the machining program, tools, and compensation values when machining is performed normally as learning data.
- the learning data is data in which the program number, tool number, and compensation information when machining is performed normally are associated with each other.
- the data acquisition unit 41 acquires the learning data, for example, from the setting information storage unit 32.
- the data acquisition unit 41 acquires learning data for cases where machining is successful, based on the machining success/failure information registered in the setting information storage unit 32.
- the data acquisition unit 41 may acquire the learning data from the machine tool 10.
- the data acquisition unit 41 sends the learning data, including the setting information, to the model generation unit 42.
- the model generation unit 42 uses the learning data to generate a trained model for inferring whether the current processing is the same as a processing that was performed successfully in the past.
- the trained model is used to determine whether the current processing and a past processing are the same processing.
- the model generation unit 42 stores the generated trained model in the trained model storage unit 21.
- the abnormality determination system 1 may be composed of one device, or may be composed of three or more devices.
- the abnormality determination system 1 may be an abnormality determination device including components of the machine tool 10 and components of the server 30.
- the abnormality determination device includes, for example, an operator input unit 11, a machining inference unit 13, a setting information storage unit 32, a setting information comparison unit 33, an abnormality detection unit 34, and a display control unit 22.
- the abnormality determination device may also include a machining program operation unit 12.
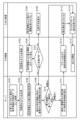
- FIG. 2 is a flowchart showing the procedure of processing executed by the abnormality determination system according to the embodiment.
- the input/output device shown in FIG. 2 is a device that receives information input by an operator, or a device that provides information to an operator.
- the input/output device here is the operator input unit 11 and the display device 23 of the machine tool 10.
- the setting information acquisition unit 31 of the server 30 acquires the setting information, the difference threshold, and the processing success/failure information from the setting information storage unit 14.
- the setting information accumulation unit 32 stores the processing success/failure information, the difference threshold, and the setting information in association with each other.
- the data acquisition unit 41 acquires, as learning data, the setting information in the case where processing was successful (step S101). That is, the data acquisition unit 41 acquires, as learning data, the setting information in which the processing success/failure information indicates that processing was successful.
- the data acquisition unit 41 acquires the learning data, for example, from the setting information accumulation unit 32, and sends it to the model generation unit 42.
- the setting information for the learning data includes, for example, a program number, a tool number, and compensation information (compensation number and compensation value). Note that the information included in the setting information for the learning data is not limited to the information described above.
- the model generation unit 42 generates a trained model using the learning data (step S102) and sends it to the machine tool 10. Specifically, the model generation unit 42 learns whether the current machining process is the same as the past machining process based on the learning data created based on a combination of the program number, tool number, and correction information when machining is performed normally. In other words, the model generation unit 42 generates a trained model that infers whether the current machining process is the same as the past machining process from the setting information when machining is performed normally by the machine tool 10.
- the model generation unit 42 may learn whether the current machining process is the same as a past machining process according to the learning data created for multiple machine tools 10.
- the model generation unit 42 may acquire learning data from multiple machine tools 10 used in the same area, or may acquire learning data collected from multiple machine tools 10 operating independently in different areas. Even when the model generation unit 42 acquires learning data from multiple machine tools 10, it learns whether the current machining process is the same as a past machining process by the same process as when learning data is acquired from one machine tool 10.
- the machine tool 10 from which learning data is collected may be added to or removed from the collection targets at any time.
- a learning device data acquisition unit 41 and model generation unit 42
- the learned model may be updated by re-learning whether or not the current machining process for the other machine tool 10 is the same as a past machining process.
- the machine tool 10 stores the learned model in the learned model storage unit 21 (step S103).
- the operator input unit 11 accepts the current setting information and difference threshold input by the operator (step S104).
- the timing at which the operator inputs the current setting information and difference threshold to the operator input unit 11 may be, for example, the timing at which the machining program is set (before the cycle starts), but is not limited to this timing.
- the difference threshold may be, for example, the allowable value of the difference when comparing a past correction value with a current correction value, but is not limited to this allowable value.
- the operator input unit 11 sends the received current setting information and difference threshold to the server 30 (step S105). Specifically, the operator input unit 11 sends the current setting information to the setting information comparison unit 33 via the machining program operation unit 12, and sends the difference threshold corresponding to the current setting information to the abnormality detection unit 34. As a result, the server 30 acquires the current setting information and difference threshold (step S106).
- the operator input unit 11 also sends the setting information to the machining inference unit 13 via the machining program operation unit 12.
- the machining inference unit 13 accepts the current setting information from the machining program operation unit 12 and reads out the learned model from the learned model storage unit 21. By inputting the current setting information into the learned model, the machining inference unit 13 determines whether the current machining process (the contents currently set in the machine tool 10) and the past machining process (the contents previously set in the machine tool 10) are the same machining process (step S107).
- the processing inference unit 13 uses the learned model stored in the learned model storage unit 21 to infer the identity of the processing by unsupervised learning. That is, the processing inference unit 13 inputs the setting information input by the operator into the learned model, and infers to which cluster the setting information belongs. In other words, the processing inference unit 13 infers whether the current processing corresponding to the setting information input by the operator corresponds to which past processing.
- the processing inference unit 13 uses a trained model learned by the model generation unit 42 of the server 30 to infer whether a processing operation is the same as a past processing operation.
- the processing inference unit 13 may obtain a trained model from an external source, such as another machine tool 10, and infer whether a processing operation is the same as a past processing operation based on this trained model.
- the inference device may also be a device separate from the machine tool 10, for example, connected to the machine tool 10 via a network.
- the learning device may be built into the machine tool 10.
- the learning device may be a device separate from the server 30, for example, connected to the server 30 via a network.
- both the learning device and the inference device may exist on the server 30.
- step S107 If the processing inference unit 13 determines that the current processing and the past processing are not the same processing (step S107, No), it sends this determination result to the display control unit 22.
- the display control unit 22 causes the display device 23 to display information indicating that the current setting information and the past setting information cannot be compared (information indicating that comparison is not possible) (step S108). This enables the machine tool 10 to notify the operator that the current correction value cannot be compared with the past correction value.
- the processing inference unit 13 determines that the current processing and the past processing are the same processing (Yes in step S107), it stores the current setting information in the setting information storage unit 14.
- the setting information acquisition unit 31 reads the current setting information from the setting information storage unit 14 and stores it in the setting information accumulation unit 32.
- the setting information comparison unit 33 receives current setting information in which a program number, compensation information, and tool number are associated with each other from the machining program operation unit 12. The setting information comparison unit 33 also reads out from the setting information storage unit 32 past compensation information that has the same program number and tool number as the program number and tool number included in the current setting information.
- the setting information comparison unit 33 compares the current setting information with the setting information accumulated in the past (step S109). Specifically, the setting information comparison unit 33 compares the correction value of the correction information included in the current setting information with the correction value of the correction information included in the past setting information.
- the setting information comparison unit 33 may compare setting information not only between the same machine tool 10, but also between different machine tools 10. In other words, the setting information comparison unit 33 may compare the current setting information with setting information previously set on a machine tool 10 different from the machine tool 10 on which the current setting information is set.
- the setting information comparison unit 33 calculates a correction value difference, which is the difference between the correction value of the correction information included in the current setting information and the correction value of the correction information included in the past setting information, and sends the correction value difference to the anomaly detection unit 34.
- the abnormality detection unit 34 determines whether the current setting information (correction value) is an abnormal value based on the correction value difference sent from the setting information comparison unit 33 and the difference threshold value sent from the operator input unit 11 (step S110).
- the abnormality detection unit 34 determines that the current correction value is an abnormal setting if the correction value difference is equal to or greater than the difference threshold, and determines that the current correction value is a normal setting if the correction value difference is smaller than the difference threshold.
- the abnormality detection unit 34 can also determine that the correction value difference is normal if it is less than a specific percentage (e.g., half) of the difference threshold, determine that there is a possibility of an abnormality if it is equal to or greater than half the difference threshold and smaller than the difference threshold, and determine that there is an abnormality if it is equal to or greater than the difference threshold.
- the abnormality detection unit 34 determines that the current correction value is appropriate (step S110, no problem)
- it sends information indicating that the current correction value is appropriate to the display control unit 22.
- the display control unit 22 causes the display device 23 to display information indicating that the correction value is appropriate.
- the machine tool 10 then enters a state in which it can accept an instruction to start machining, i.e., a state in which it can accept a cycle start instruction.
- the abnormality detection unit 34 determines that the current correction value is inappropriate (step S110, there is a problem), it sends an alarm to the display control unit 22 indicating that the current correction value is inappropriate.
- the abnormality detection unit 34 determines that the current correction value is inappropriate, it acquires from the setting information comparison unit 33 the past correction value (the correction value accumulated in the past) used for comparison by the setting information comparison unit 33.
- the abnormality detection unit 34 calculates a reset candidate value based on the acquired correction value accumulated in the past (step S111).
- the previously stored correction values used by the abnormality detection unit 34 are not limited to correction values used on the same machine tool 10, but may be correction values used on a machine tool 10 other than the machine tool 10 on which the current correction value is set.
- the anomaly detection unit 34 sends the determined reset candidate value to the display control unit 22. For example, the anomaly detection unit 34 sends the average value of previously accumulated correction values to the display control unit 22 as the reset candidate value. The anomaly detection unit 34 may also send a range of previously accumulated normal correction values to the display control unit 22 as the reset candidate value. The anomaly detection unit 34 may also send the reset candidate value represented in a histogram, taking into account the frequency of use as a normal correction value, to the display control unit 22. In other words, the anomaly detection unit 34 may send a histogram including information on the frequency of use of past correction values used as normal correction values to the display control unit 22 as the reset candidate value.
- the display control unit 22 of the machine tool 10 outputs an alarm indicating that the correction value is inappropriate and the reset candidate value to the display device 23 (step S112). This causes the display device 23 to display the alarm and the reset candidate value.
- the display device 23 may display the reset candidate values in a list, may display them in a histogram, or may display the reset candidate value that has been used most frequently (the most frequent value). After the reset candidate value is displayed, the machine tool 10 is ready to accept a correction value from the operator.
- the operator input unit 11 accepts the correction value input by the operator (step S113). That is, the operator input unit 11 accepts the problem solution (revised correction value) input by the operator based on the alarm and the reset candidate value displayed on the machine tool 10.
- the machine tool 10 may use the current correction value. That is, the machine tool 10 may use a corrected correction value input by the operator, or may use the original correction value as is.
- the machine tool 10 receives the correction value, it becomes capable of receiving an instruction to start machining, i.e., a cycle start instruction.
- the operator input unit 11 accepts the cycle start instruction (step S114).
- the operator input unit 11 accepts the cycle start instruction, for example, when a cycle start button for instructing the start of machining is pressed. This causes the machine tool 10 to start machining (cycle start) using the input correction value (step S115).
- the machine tool 10 completes machining, the shape of the finished product is measured and a determination is made as to whether it was completed successfully.
- the machine tool 10 accepts machining success/failure information, which is the result of the success/failure determination, and stores it in the setting information storage unit 14.
- the machine tool 10 associates the setting information with the machining success/failure information and stores them in the setting information storage unit 14. As a result, the setting information stored in the setting information storage unit 14 becomes past setting information.
- the setting information acquisition unit 31 reads out past setting information, difference threshold, and processing success/failure information from the setting information storage unit 14.
- the setting information acquisition unit 31 stores the past setting information, difference threshold, and processing success/failure information in the setting information accumulation unit 32. As a result, the past setting information, difference threshold, and processing success/failure information are accumulated in the setting information accumulation unit 32.
- the setting information acquisition unit 31 may store the current setting information in the setting information accumulation unit 32 when the current processing is being performed, and store the processing success/failure information in the setting information accumulation unit 32 after the current processing is completed. In this case, too, the setting information acquisition unit 31 associates the setting information, the difference threshold, and the processing success/failure information and stores them in the setting information storage unit 14. Storing the setting information, the difference threshold, and the processing success/failure information in the setting information storage unit 14 may be performed periodically at a specific cycle.
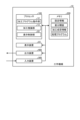
- FIG. 3 is a diagram showing an example of a hardware configuration for realizing a machine tool according to an embodiment.
- the machine tool 10 can be realized by an input device 300, a processor 100, a memory 200, an output device 400, and a display device 23.
- An example of the processor 100 is a CPU (also called a Central Processing Unit, central processing unit, processing unit, arithmetic unit, microprocessor, microcomputer, or DSP (Digital Signal Processor)) or a system LSI (Large Scale Integration).
- An example of the memory 200 is a RAM (Random Access Memory) or a ROM (Read Only Memory).
- the machine tool 10 is realized by the processor 100 reading and executing a computer-executable processing program for executing the operation of the machine tool 10 stored in the memory 200.
- the processing program for executing the operation of the machine tool 10 can also be said to cause the computer to execute the procedure or method of the machine tool 10.
- the processing program executed by the machine tool 10 is modular, including a machining program operation unit 12, a machining inference unit 13, and a display control unit 22, which are loaded onto the main memory device and generated on the main memory device.
- the processing programs executed by the machine tool 10 include a program that associates program numbers, correction information, and tool numbers, a program that infers whether the current processing operation and the previous processing operation are the same processing operation, and a program that displays various information on the display device 23.
- the input device 300 accepts setting information and the like from the operator and sends it to the processor 100.
- the processing executed by the input device 300 corresponds to the processing executed by the operator input unit 11.
- Memory 200 stores setting information, difference threshold, processing success/failure information, processing programs, etc. Setting information, difference threshold, processing success/failure information, and processing programs are read from memory 200 by processor 100. Memory 200 is also used as a temporary memory when processor 100 executes various processes.
- the processing executed by the output device 400 corresponds to the processing in which the machine tool 10 transmits information to the server 30.
- the output device 400 sends various information, such as setting information, to the server 30.
- the processing program may be provided as a computer program product in the form of an installable or executable file stored on a computer-readable storage medium.
- the processing program may also be provided to the machine tool 10 via a network such as the Internet. Note that some of the functions of the machine tool 10 may be realized by dedicated hardware such as a dedicated circuit, and some by software or firmware.
- the machine tool 10 of this embodiment determines whether the current machining is the same as the past machining, and if it is the same, the server 30 determines whether the current correction value is abnormal, and if it is abnormal, displays a reset candidate value and an alarm. In this way, the abnormality determination system 1 can notify the operator of a defective correction value before machining begins, preventing the occurrence of a machining defect from being overlooked.
- the abnormality determination system 1 uses a learned model to determine whether the current machining is identical to the past machining, it can perform an even more accurate determination of identity by utilizing not only the correction value of one machine tool 10 but also the correction values of other machine tools 10. In addition, since the abnormality determination system 1 calculates the reset candidate values using the correction values of other machine tools 10, it can provide the operator with even more accurate reset candidate values.
- the abnormality determination system 1 determines that there is a possibility of an abnormality when, for example, the correction value difference is equal to or greater than half the difference threshold value and is smaller than the difference threshold value, and notifies the operator. As a result, even when it is difficult to automatically determine whether or not an abnormality will lead to a machining defect, the abnormality determination system 1 can alert the operator, which can lead to the prevention of machining defects.
- the abnormality determination system 1 displays, for example, a list of reset candidate values. This allows the operator to easily understand the multiple reset candidate values and easily select an appropriate reset candidate value from among the multiple reset candidate values.
- the abnormality determination system 1 also displays the reset candidate values, for example, in a histogram. This allows the operator to easily grasp the trend of the reset candidate values, making it easy to select appropriate reset candidate values.
- the abnormality determination system 1 also displays, for example, the most frequent value of the reset candidate values. This makes it easy to grasp the trend of the reset candidate values, and makes it easy to select an appropriate reset candidate value.
- the abnormality determination system 1 is able to cause the machine tool 10 to perform machining with an appropriate correction value that corresponds to the selected appropriate reset candidate value.
- the processing inference unit 13 infers whether the current processing is the same as the past processing using a learned model, but the processing inference unit 13 may also make inference based on the comparison results of the program name, program number, tool number, etc. In this case, it becomes possible to easily implement a device for making inference.
- the abnormality determination system 1 of the embodiment detects an abnormality in the current correction value based on the difference between the current correction value set in the machine tool 10 and the previous correction value that was set when machining was performed appropriately in the past. Then, when the abnormality determination system 1 detects an abnormality, it causes the display device 23 to display information indicating that the current correction value is inappropriate. In this way, the abnormality determination system 1 can perform machining while reducing the possibility of correction with an inappropriate correction value. In this way, the abnormality determination system 1 can detect errors in the settings of the tool before machining begins, thereby preventing machining defects.
- 1 Abnormality judgment system 10 Machine tool, 11 Operator input section, 12 Machining program operation section, 13 Machining inference section, 14 Setting information storage section, 21 Learned model storage section, 22 Display control section, 23 Display device, 30 Server, 31 Setting information acquisition section, 32 Setting information accumulation section, 33 Setting information comparison section, 34 Abnormality detection section, 41 Data acquisition section, 42 Model generation section, 100 Processor, 200 Memory, 300 Input device, 400 Output device.
Landscapes
- Engineering & Computer Science (AREA)
- Human Computer Interaction (AREA)
- Manufacturing & Machinery (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Numerical Control (AREA)
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2023/015523 WO2024218878A1 (ja) | 2023-04-18 | 2023-04-18 | 異常判定装置、異常判定システム、および異常判定方法 |
| CN202380097131.3A CN120936959A (zh) | 2023-04-18 | 2023-04-18 | 异常判定装置、异常判定系统及异常判定方法 |
| JP2023552359A JP7412655B1 (ja) | 2023-04-18 | 2023-04-18 | 異常判定装置、異常判定システム、および異常判定方法 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2023/015523 WO2024218878A1 (ja) | 2023-04-18 | 2023-04-18 | 異常判定装置、異常判定システム、および異常判定方法 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024218878A1 true WO2024218878A1 (ja) | 2024-10-24 |
Family
ID=89451962
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2023/015523 Ceased WO2024218878A1 (ja) | 2023-04-18 | 2023-04-18 | 異常判定装置、異常判定システム、および異常判定方法 |
Country Status (3)
| Country | Link |
|---|---|
| JP (1) | JP7412655B1 (enExample) |
| CN (1) | CN120936959A (enExample) |
| WO (1) | WO2024218878A1 (enExample) |
Families Citing this family (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20250144051A (ko) | 2024-03-26 | 2025-10-10 | 주식회사 팔복인더스트리 | 전기 이중층 커패시터 조립 장치용 전동 액추에이터 원격 모니터링 시스템 |
| WO2026088316A1 (ja) * | 2024-10-23 | 2026-04-30 | ファナック株式会社 | 作業誤り判断装置 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2019086928A (ja) * | 2017-11-06 | 2019-06-06 | ファナック株式会社 | 制御装置及び機械学習装置 |
| JP2020035287A (ja) * | 2018-08-31 | 2020-03-05 | ファナック株式会社 | 知識作成システム |
| JP2021009480A (ja) * | 2019-06-28 | 2021-01-28 | ファナック株式会社 | パラメータ管理装置及びその管理システム |
| JP2021015573A (ja) * | 2019-07-16 | 2021-02-12 | ファナック株式会社 | 異常判定装置及び異常判定システム |
| JP2021117847A (ja) * | 2020-01-28 | 2021-08-10 | 株式会社山本金属製作所 | 加工状態表示装置 |
-
2023
- 2023-04-18 JP JP2023552359A patent/JP7412655B1/ja active Active
- 2023-04-18 WO PCT/JP2023/015523 patent/WO2024218878A1/ja not_active Ceased
- 2023-04-18 CN CN202380097131.3A patent/CN120936959A/zh active Pending
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2019086928A (ja) * | 2017-11-06 | 2019-06-06 | ファナック株式会社 | 制御装置及び機械学習装置 |
| JP2020035287A (ja) * | 2018-08-31 | 2020-03-05 | ファナック株式会社 | 知識作成システム |
| JP2021009480A (ja) * | 2019-06-28 | 2021-01-28 | ファナック株式会社 | パラメータ管理装置及びその管理システム |
| JP2021015573A (ja) * | 2019-07-16 | 2021-02-12 | ファナック株式会社 | 異常判定装置及び異常判定システム |
| JP2021117847A (ja) * | 2020-01-28 | 2021-08-10 | 株式会社山本金属製作所 | 加工状態表示装置 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7412655B1 (ja) | 2024-01-12 |
| CN120936959A (zh) | 2025-11-11 |
| JPWO2024218878A1 (enExample) | 2024-10-24 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6616375B2 (ja) | 状態判定装置 | |
| CN110088699B (zh) | 信息处理方法、信息处理系统以及信息处理装置 | |
| JP7412655B1 (ja) | 異常判定装置、異常判定システム、および異常判定方法 | |
| JP6693919B2 (ja) | 制御装置及び機械学習装置 | |
| US10725465B2 (en) | State diagnostic device | |
| EP2950177A1 (en) | Asset condition monitoring | |
| CN117193164B (zh) | 一种数控机床的故障监测方法及系统 | |
| CN112025766B (zh) | 一种机器人系统健康自检的方法、装置以及电子设备 | |
| JP7748871B2 (ja) | 加工異常検知方法及び加工異常検知装置 | |
| CN114902060B (zh) | 机器学习装置及机器学习方法 | |
| CN113544486A (zh) | 故障诊断系统、预测规则生成方法及预测规则生成程序 | |
| CN113110390B (zh) | 一种车辆故障识别方法、装置、电子设备及存储介质 | |
| CN105393178A (zh) | 可编程逻辑控制器 | |
| JP7457601B2 (ja) | 要因推定装置、要因推定システムおよびプログラム | |
| US20080071490A1 (en) | Industrial process evaluation system, industrial process evaluation method and recording medium storing industrial process evaluation program | |
| JP2022088713A (ja) | 物品の組立工程における検査システム | |
| JP2022038020A (ja) | 検査システム | |
| JP7167714B2 (ja) | 異常判定装置、異常判定方法、及び異常判定プログラム | |
| JPWO2024218878A5 (enExample) | ||
| JP2009252137A (ja) | 予防保全システム | |
| CN112543944B (zh) | 信息管理装置以及信息管理方法 | |
| JP2025511956A (ja) | 人工知能モデルベースの異常診断方法、これを用いた異常診断装置及び工場モニタリングシステム | |
| JP2001022441A (ja) | プラント監視装置 | |
| TWI887633B (zh) | 工廠運轉支援系統 | |
| EP4597246A1 (en) | Factor analysis device and factor analysis method |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023552359 Country of ref document: JP |
|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 23934024 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 23934024 Country of ref document: EP Kind code of ref document: A1 |