WO2023276221A1 - 画像処理システム、画像処理装置、及び画像処理方法 - Google Patents
画像処理システム、画像処理装置、及び画像処理方法 Download PDFInfo
- Publication number
- WO2023276221A1 WO2023276221A1 PCT/JP2022/004035 JP2022004035W WO2023276221A1 WO 2023276221 A1 WO2023276221 A1 WO 2023276221A1 JP 2022004035 W JP2022004035 W JP 2022004035W WO 2023276221 A1 WO2023276221 A1 WO 2023276221A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- image processing
- noise
- image data
- noise reduction
- transmission line
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N5/00—Details of television systems
- H04N5/14—Picture signal circuitry for video frequency region
- H04N5/21—Circuitry for suppressing or minimising disturbance, e.g. moiré or halo
- H04N5/213—Circuitry for suppressing or minimising impulsive noise
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04B—TRANSMISSION
- H04B1/00—Details of transmission systems, not covered by a single one of groups H04B3/00 - H04B13/00; Details of transmission systems not characterised by the medium used for transmission
- H04B1/06—Receivers
- H04B1/10—Means associated with receiver for limiting or suppressing noise or interference
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04B—TRANSMISSION
- H04B1/00—Details of transmission systems, not covered by a single one of groups H04B3/00 - H04B13/00; Details of transmission systems not characterised by the medium used for transmission
- H04B1/38—Transceivers, i.e. devices in which transmitter and receiver form a structural unit and in which at least one part is used for functions of transmitting and receiving
- H04B1/3822—Transceivers, i.e. devices in which transmitter and receiver form a structural unit and in which at least one part is used for functions of transmitting and receiving specially adapted for use in vehicles
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04N—PICTORIAL COMMUNICATION, e.g. TELEVISION
- H04N13/00—Stereoscopic video systems; Multi-view video systems; Details thereof
- H04N13/20—Image signal generators
- H04N13/204—Image signal generators using stereoscopic image cameras
- H04N13/239—Image signal generators using stereoscopic image cameras using two two-dimensional [2D] image sensors having a relative position equal to or related to the interocular distance
Definitions
- the present invention relates to an image processing system, an image processing apparatus, and an image processing method for correcting image data from a camera transmitted via a transmission line.
- the stereo camera device simultaneously measures visual information from images and distance information to an object, so it can detect various objects (people, cars, three-dimensional objects, road surfaces, road signs, signboard signs) around the car. etc.) can be grasped in detail, and it is said that it will also contribute to the improvement of safety during driving support.
- Patent Document 1 Japanese Patent Laid-Open No. 2004-100000 describes reducing large unnecessary radiation noise generated when image data signals, clock signals, and image synchronization signals transmitted from two imaging units are transmitted to an image processing unit in an on-vehicle camera device. It is
- the signals transmitted from the two imaging units are temporally shifted to reduce the amount of noise on the signal line, but no consideration is given to reducing communication errors due to external noise.
- an object of the present invention is to provide an image processing system, an image processing apparatus, and an image processing method capable of reducing communication errors due to external noise on the image data transmission line.
- the present invention includes an in-vehicle camera that acquires external information, an image processing device that is installed separately from the in-vehicle camera and processes image data acquired by the in-vehicle camera, and an in-vehicle camera and the image processing device.
- an image processing system comprising a transmission line for transmitting image data by connecting the A noise source detection processing unit that determines whether or not an object registered in advance as a source is included in the image data; Accordingly, it has a noise reduction parameter determination unit that changes the parameters of the noise reduction filter.
- an image processing system an image processing apparatus, and an image processing method capable of reducing communication errors due to external noise on transmission lines for image data.
- FIG. 1 is a configuration block diagram of a conventional image processing system which is a premise of Embodiment 1;
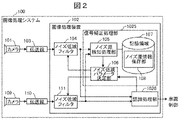
- FIG. 2 is a functional configuration block diagram of the image processing system in Embodiment 1.
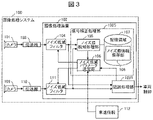
- FIG. FIG. 11 is a functional configuration block diagram of an image processing system according to Embodiment 2;
- an image processing system using an in-vehicle camera installed in a car will be described as an example.
- the image data acquired from the CMOS image sensor that constitutes the in-vehicle camera is transmitted through a transmission line using a communication IC such as Serdes (Serializer/Deserializer), which is a circuit that mutually converts serial data and parallel data. is assumed to be serially transmitted.
- Serdes Serializer/Deserializer
- FIG. 1 is a configuration block diagram imagining the hardware of a conventional image processing system, which is the premise of this embodiment.
- an image processing system 100 includes a camera 101, an image processing device 102, and a transmission line 103 connecting them.
- the camera 101 is composed of a CMOS image sensor 1011, a communication IC (Tx) 1012, and a connector section (Tx) 1013.
- the image processing device 102 is composed of a connector section (Rx) 1021 , a communication IC (Rx) 1022 and a microcomputer 1024 .
- the microcomputer 1024 is composed of a processor such as a general CPU (Central Processing Unit) and a storage device. Recognition processing of the target object is executed by software processing, and vehicle control is performed according to the recognition result.
- the communication IC (Rx) 1022 which is the communication IC on the receiving side, is equipped with an equalizer such as a Continuous Time Linear Equalizer (hereinafter referred to as CTLE) and a Decision Feedback Equalizer (hereinafter referred to as DFE) to ensure communication quality.
- CTLE Continuous Time Linear Equalizer
- DFE Decision Feedback Equalizer
- CTLE may also amplify noise components, so there is a tendency to use DFE in addition to CTLE in high-speed communication.
- the DFE performs correction using feedback control, but if there is a radio tower or wireless communication area around the vehicle, or if wireless communication is performed nearby, it may receive large external noise in a short period of time. . If this external noise exceeds the correctable range of the equalizer, there is a possibility that the correction control by the equalizer will not keep up and a communication error will occur.
- FIG. 2 is a functional configuration block diagram of the image processing system in this embodiment.
- the same functions as in FIG. 1 are given the same reference numerals, and the description thereof is omitted. 2 differs from FIG. 1 in that it has a configuration using a stereo camera and has two systems of cameras, transmission lines, and noise reduction filters, and that it has a signal correction processing unit 1025 .
- the image processing system 100 is an image processing system that performs three-dimensional object detection by processing parallax images using a stereo camera as means for detecting nearby vehicles. It should be noted that, for example, detection of a three-dimensional object using only a monocular camera or a combination of a monocular camera and radar can also be used. Also, three or more cameras may be used.
- a stereo image is captured by camera 101 and camera 109 .
- Image processor 102 receives image data via transmission lines 103 and 110 .
- the captured image data is sent to the recognition processing unit 1026 through the noise reduction filters 104 and 111, and the distance information to the object is calculated by processing the parallax image and the object is recognized.
- the noise reduction filters 104 and 111 that correct captured image data have their correction amounts controlled by the signal correction processing unit 1025 . That is, the captured image data from the noise reduction filters 104 and 111 are sent to the noise source detection processing unit 105 as external world information.
- the noise source detection processing unit 105 refers to the external world information and the image of the object registered in the noise source information storage unit 108 stored in advance in the storage area 107, and the noise source and the noise source are included in the image data of the external world information. It is determined whether or not a target object is included. Then, when the object is included, the noise source detection processing unit 105 acquires detailed information of the noise source such as the frequency and noise level corresponding to the object registered in the noise source information storage unit 108 .
- Examples of the external world information acquired by the camera include images of steel towers, lightning, mobile phone base stations, pantographs, radio communication taxis, relay vehicles, military vehicles, and signs such as high-voltage power transmission, and noise sources.
- the detection processing unit 105 acquires information using them as noise sources.
- the acquired detailed information of the noise source and the distance information to the noise source calculated by the recognition processing unit 1026 are sent to the noise reduction parameter determination unit 106 .
- the noise reduction parameter determination unit 106 determines the correction amount of the noise reduction filter from the sent information, and corrects the parameters of the noise reduction filter. That is, the parameters of the noise reduction filter are corrected by feedforward control.
- the signal correction processing unit 1025 first confirms the captured image, and when it confirms a noise source target in the image, starts correcting the filter. It should be noted that filter correction processing is not performed unless a noise source is confirmed in the captured image. Then, the frequency and noise level of the noise source are specified from the image of the external information, and the correction amount and correction timing of the noise reduction filter are determined by one or more of the frequency, noise level, and distance information to the noise source. to suppress communication errors caused by external noise.
- the noise reduction filter is corrected using, for example, an equalizer in Serdes.
- Serdes usually have two types of equalizers, CTLE and DFE, for filter correction.
- the DFE noise correction parameter can set the amount of noise correction by changing the register setting. For example, by rewriting the register area for setting the noise correction amount using an interface provided by Serdes such as I2C (Inter-Integrated Circuit), the preset correction amount can be corrected in real time within a certain range.
- the noise source is discriminated from the captured image, which is the external information, and the parameters of the noise reduction filter are changed according to the noise source, thereby suppressing the occurrence of communication errors and increasing the reliability. high communication processing becomes possible. Accordingly, it is possible to provide an image processing system, an image processing apparatus, and an image processing method capable of reducing communication errors due to external noise on the image data transmission line.
- FIG. 3 is a functional configuration block diagram of the image processing system in this embodiment.
- the same functions as in FIG. 2 are given the same reference numerals, and the description thereof is omitted.
- FIG. 3 differs from FIG. 2 in that vehicle speed information 112 is provided as an input to noise reduction parameter determining section 106 .
- the noise reduction parameter determination unit 106 performs processing such as shortening the interval between correction timings of the noise reduction filter when the vehicle speed is high according to the vehicle speed information.
- the parameters of the noise reduction filter can be changed at more optimal correction timing of the noise reduction filter, and more reliable communication processing can be performed. It becomes possible.
- the present invention is not limited to the above embodiments, and includes various modifications.
- noise reduction in the transmission of image data has been described in the above embodiments
- the present invention is not limited to image data and can also be applied to audio data.
- the above-described embodiments have been described in detail in order to explain the present invention in an easy-to-understand manner, and are not necessarily limited to those having all the described configurations.
- Noise source information storage unit 112 Vehicle speed information 1011: CMOS image sensor 1012: Communication IC (Tx) 1013: Connector unit (Tx) 1021: Connector unit (Rx) 1022: Communication IC (Rx), 1024: microcomputer, 1025: signal correction processing section, 1026 recognition processing section
Landscapes
- Engineering & Computer Science (AREA)
- Signal Processing (AREA)
- Multimedia (AREA)
- Computer Networks & Wireless Communication (AREA)
- Image Processing (AREA)
Abstract
画像データの伝送線上での外部ノイズによる通信エラーの低減が可能な画像処理システム、画像処理装置、及び画像処理方法を提供する。 そのために、外界情報を取得する車載カメラと、車載カメラとは別体で設置され車載カメラで取得した画像データを処理する画像処理装置と、車載カメラと画像処理装置をつなぎ画像データを伝送する伝送線からなる画像処理システムであって、画像処理装置は、伝送線でのノイズを低減するノイズ低減フィルタと、処理プロセッサを有し、処理プロセッサは、伝送線に対するノイズ源としてあらかじめ登録された対象物が画像データに含まれるか否かを判定するノイズ源検知処理部と、画像データにノイズ源が含まれる場合に、あらかじめ登録されたノイズ源の周波数またはノイズレベルに応じて、ノイズ低減フィルタのパラメータを変更するノイズ低減パラメータ決定部を有する。
Description
本発明は、伝送線を介して伝送されるカメラからの画像データを補正する画像処理システム、画像処理装置、及び画像処理方法に関する。
近年、車載カメラ装置の普及により、安全運転や自動運転に向けた各種認識機能への要求が高まってきている。なかでも、ステレオカメラ装置は、画像による視覚的な情報と、対象物への距離情報を同時に計測するため、自動車周辺の様々な対象物(人、車、立体物、路面、路面標識、看板標識など)を詳細に把握でき、運転支援時の安全性の向上にも寄与するとされている。
しかしながら、カメラに使用するCMOSイメージセンサの解像度が増大するにつれ、画像処理を行うマイコンの発熱量が増加し、CMOSイメージセンサと画像処理用マイコンを同一の筐体内に収めることが難しくなっている。そのため、カメラと画像処理用マイコンを搭載する画像処理基板を別体とし、カメラからの画像データを伝送線を介して伝送する構成が考えられる。その場合、伝送線上でのノイズが問題となる。
本技術分野の背景技術として、例えば、特許文献1がある。特許文献1には、車載カメラ装置において、2つの撮像部から送信される画像データ信号やクロック信号、画像の同期信号を画像処理部へ伝送する時に発生する大きな不要輻射ノイズを低減することが記載されている。
特許文献1は、2つの撮像部から送信する信号を時間的にずらして信号線上のノイズ量を低減しているが、外部ノイズによる通信エラーの低減については考慮されていない。
本発明は上記課題に鑑み、画像データの伝送線上での外部ノイズによる通信エラーの低減が可能な画像処理システム、画像処理装置、及び画像処理方法を提供することを目的とする。
本発明は、その一例を挙げるならば、外界情報を取得する車載カメラと、車載カメラとは別体で設置され車載カメラで取得した画像データを処理する画像処理装置と、車載カメラと画像処理装置をつなぎ画像データを伝送する伝送線からなる画像処理システムであって、画像処理装置は、伝送線でのノイズを低減するノイズ低減フィルタと、処理プロセッサを有し、処理プロセッサは、伝送線に対するノイズ源としてあらかじめ登録された対象物が画像データに含まれるか否かを判定するノイズ源検知処理部と、画像データにノイズ源が含まれる場合に、あらかじめ登録されたノイズ源の周波数またはノイズレベルに応じて、ノイズ低減フィルタのパラメータを変更するノイズ低減パラメータ決定部を有する。
本発明によれば、画像データの伝送線上での外部ノイズによる通信エラーの低減が可能な画像処理システム、画像処理装置、及び画像処理方法を提供できる。
以下、本発明を実施例について図面を参照して説明する。
本実施例では、自動車に搭載する車載カメラによる画像処理システムを例にして説明する。そして、車載カメラを構成するCMOSイメージセンサから取得した画像データを、シリアルデータとパラレルデータを相互変換する回路であるSerdes(Serializer/Deserializer)などの通信ICを使用して、伝送線を介してデータをシリアル伝送する構成を前提に説明する。
図1は、本実施例の前提となる従来の画像処理システムのハードウェアをイメージした構成ブロック図である。図1において、画像処理システム100は、カメラ101と画像処理装置102と、それらをつなぐ伝送線103で構成されている。
カメラ101は、CMOSイメージセンサ1011、通信IC(Tx)1012、コネクタ部(Tx)1013で構成される。
また、画像処理装置102は、コネクタ部(Rx)1021、通信IC(Rx)1022、マイコン1024で構成される。なお、マイコン1024は、一般的なCPU(Central Processing Unit)等の処理プロセッサと記憶装置で構成され、処理プロセッサが、記憶装置からそれぞれの機能を実現するプログラムや情報を読み出して、例えばカメラで撮像した対象物の認識処理をソフトウェア処理することにより実行し、その認識結果に応じて車両制御を行う。
Serdesを使用した通信手法では、そのままでは、基板、コネクタ、伝送線をはじめとした通信経路上の損失などで信号が劣化し、正常な通信を行うことが難しい。そのため既存技術では、受信側の通信ICである通信IC(Rx)1022に、通信品質の確保のためContinuous Time Linear Equalizer(以下、CTLE)、Decision Feedback Equalizer(以下、DFE)などの等化器の機能が搭載されており、この機能を使用して信号波形が劣化した場合に波形の補正を行っている。なお、図1では、通信IC(Rx)1022内のDFEをノイズ低減フィルタ104としている。
通常の補正であればCTLEで対応可能であるが、CTLEはノイズ成分も増幅する可能性が有るため、高速通信ではCTLEに加えてDFEを併用する傾向にある。DFEはフィードバック制御を用いた補正を行うが、車両の周囲に電波塔や無線通信エリアなどがある場合、また近傍で無線通信が行われた場合等、短時間に大きな外部ノイズを受ける場合がある。この外部ノイズが等化器の補正可能範囲を超えた場合、等化器による補正制御が間に合わず通信エラーが発生する可能性が有る。
そこで、本実施例では、外界情報からノイズ源を確認することで、ノイズ源に応じたノイズ低減フィルタのパラメータを変更することで信頼性の高い通信処理を可能とする。以下、本実施例の詳細について説明する。
図2は本実施例における画像処理システムの機能構成ブロック図である。図2において、図1と同じ機能は同じ符号を付し、その説明は省略する。図2において、図1と異なる点は、ステレオカメラを用いた構成としておりカメラと伝送線とノイズ低減フィルタが2系統ある点と、信号補正処理部1025を有している点である。
図2において、画像処理システム100は、近方の車両検知手段としてステレオカメラを用いた視差画像の処理による立体物検知を行う画像処理システムである。なお、例えば単眼カメラのみや、単眼カメラとレーダを組み合わせた立体物検知などによっても実施可能である。また、3つ以上の複数のカメラを用いてもよい。
ステレオ画像は、カメラ101およびカメラ109によって撮像される。画像処理装置102は伝送線103および110を経由して画像データを受け取る。撮像された画像データは、ノイズ低減フィルタ104および111を通して認識処理部1026に送られ、視差画像の処理による対象物との距離情報の算出、及び対象物の認識処理を行う。
一方、撮像された画像データの補正を行うノイズ低減フィルタ104および111は、信号補正処理部1025によって補正量を制御される。すなわち、ノイズ低減フィルタ104および111からの撮像された画像データは、外界情報としてノイズ源検知処理部105に送られる。ノイズ源検知処理部105では、外界情報と、あらかじめ記憶領域107に収められたノイズ源情報保存部108に登録された対象物の画像とを参照して、外界情報の画像データ内にノイズ源となる対象物が含まれるか否かを判定する。そして、対象物が含まれる場合、ノイズ源検知処理部105は、ノイズ源情報保存部108に登録された、その対象物に対応した周波数やノイズレベルなどのノイズ源の詳細情報を取得する。
カメラで取得する外界情報としては、例えば、鉄塔、雷、携帯電話基地局、パンタグラフや、無線通信を行うタクシー、中継車両、軍用車両、また、高圧送電などの標識等の画像であり、ノイズ源検知処理部105は、それらをノイズ源とする情報を取得する。
取得したノイズ源の詳細情報と、認識処理部1026で算出したノイズ源までの距離情報は、ノイズ低減パラメータ決定部106に送られる。ノイズ低減パラメータ決定部106では、この送られた情報から、ノイズ低減フィルタの補正量を決定し、ノイズ低減フィルタのパラメータを補正する。すなわち、ノイズ低減フィルタのパラメータをフィードフォワード制御により補正する。
このように、信号補正処理部1025は、まず撮像された画像を確認し、画像内にノイズ源となる対象を確認した場合、フィルタの補正を開始する。なお、撮像された画像にノイズ源が確認されなければフィルタの補正処理は実施しない。そして、ノイズ源の周波数やノイズレベルを外界情報の画像から特定し、周波数、ノイズレベル、ノイズ源までの距離情報の何れか1つ、または複数の情報によって、ノイズ低減フィルタの補正量と補正タイミングを変更するよう信号を送信し、外部ノイズによる通信エラーを抑制する。
なお、ノイズ低減フィルタの補正は、例えばSerdes内のイコライザを用いて実施する。通常Serdesは、フィルタ補正用としてCTLEとDFEの2種のイコライザをもつ。またDFEのノイズ補正パラメータは、レジスタ設定を変更することで、ノイズの補正量を設定することができる。例えば、ノイズ補正量を設定するレジスタ領域を、I2C(Inter-Integrated Circuit)などのSerdesが備えるインターフェースを用いて書き換えることで、あらかじめ設定した補正量を一定の範囲でリアルタイムに補正することができる。
このように、本実施例によれば、外界情報である撮像した画像からノイズ源を判別し、ノイズ源に応じてノイズ低減フィルタのパラメータを変更することで通信エラーの発生を抑制し、信頼性の高い通信処理が可能となる。これにより、画像データの伝送線上での外部ノイズによる通信エラーの低減が可能な画像処理システム、画像処理装置、及び画像処理方法を提供できる。
図3は本実施例における画像処理システムの機能構成ブロック図である。図3において、図2と同じ機能は同じ符号を付し、その説明は省略する。図3において、図2と異なる点は、ノイズ低減パラメータ決定部106への入力として、車速情報112を設けた点である。
車速が早いと単位時間当たりの移動距離が大きくなる。そのために、図3に示すように、ノイズ低減パラメータ決定部106において、車速情報により車速が早い場合は、ノイズ低減フィルタの補正タイミングの間隔を短くする等の処理を行う。
このように、本実施例によれば、実施例1の効果に加えて、より最適なノイズ低減フィルタの補正タイミングでノイズ低減フィルタのパラメータを変更することができ、より信頼性の高い通信処理が可能となる。
以上実施例について説明したが、本発明は上記した実施例に限定されるものではなく、様々な変形例が含まれる。例えば、上記した実施例では画像データの伝送におけるノイズ低減について説明したが、画像データに限定するものではなく、音声データについても適用可能である。また、上記した実施例は本発明を分かりやすく説明するために詳細に説明したものであり、必ずしも説明した全ての構成を備えるものに限定されるものではない。
100:画像処理システム、101、109:カメラ、102:画像処理装置、103、110:伝送線、104、111:ノイズ低減フィルタ、105:ノイズ源検知処理部、106:ノイズ低減パラメータ決定部、107:記憶領域、108:ノイズ源情報保存部、112:車速情報、1011:CMOSイメージセンサ、1012:通信IC(Tx)、1013:コネクタ部(Tx)、1021:コネクタ部(Rx)、1022:通信IC(Rx)、1024:マイコン、1025:信号補正処理部、1026認識処理部
Claims (10)
- 外界情報を取得する車載カメラと、前記車載カメラとは別体で設置され前記車載カメラで取得した画像データを処理する画像処理装置と、前記車載カメラと前記画像処理装置をつなぎ前記画像データを伝送する伝送線からなる画像処理システムであって、
前記画像処理装置は、前記伝送線でのノイズを低減するノイズ低減フィルタと、処理プロセッサを有し、
前記処理プロセッサは、
前記伝送線に対するノイズ源としてあらかじめ登録された対象物が前記画像データに含まれるか否かを判定するノイズ源検知処理部と、
前記画像データに前記ノイズ源が含まれる場合に、あらかじめ登録された前記ノイズ源の周波数またはノイズレベルに応じて、前記ノイズ低減フィルタのパラメータを変更するノイズ低減パラメータ決定部を有することを特徴とする画像処理システム。 - 請求項1に記載の画像処理システムにおいて、
前記車載カメラは複数であって、複数の前記車載カメラからのそれぞれの画像データを伝送する複数の伝送線を有し、
前記複数の伝送線からのそれぞれの画像データのノイズを低減する複数の前記ノイズ低減フィルタを有し、
前記処理プロセッサは、
複数の前記車載カメラからの視差画像の処理による対象物との距離情報を算出し、
前記ノイズ低減パラメータ決定部は、前記対象物との距離情報に応じて、複数の前記ノイズ低減フィルタのそれぞれのパラメータを補正することを特徴とする画像処理システム。 - 請求項1に記載の画像処理システムにおいて、
前記ノイズ低減パラメータ決定部は、車速情報を用いて前記ノイズ低減フィルタのパラメータの補正タイミングを決定することを特徴とする画像処理システム。 - 請求項1に記載の画像処理システムにおいて、
前記画像データの伝送は、Serdesを用いたシリアル伝送であって、
前記ノイズ低減フィルタは、通信IC内の等化器であることを特徴とする画像処理システム。 - 外界情報を取得する車載カメラからの画像データを伝送線を介して入力し処理する画像処理装置であって、
前記伝送線でのノイズを低減するノイズ低減フィルタと、処理プロセッサを有し、
前記処理プロセッサは、
前記伝送線に対するノイズ源としてあらかじめ登録された対象物が前記画像データに含まれるか否かを判定するノイズ源検知処理部と、
前記画像データに前記ノイズ源が含まれる場合に、あらかじめ登録された前記ノイズ源の周波数またはノイズレベルに応じて、前記ノイズ低減フィルタのパラメータを変更するノイズ低減パラメータ決定部を有することを特徴とする画像処理装置。 - 請求項5に記載の画像処理装置において、
前記車載カメラは複数であって、それぞれの前記車載カメラからの画像データを伝送する複数の伝送線からのそれぞれの画像データのノイズを低減する複数の前記ノイズ低減フィルタを有し、
前記処理プロセッサは、
複数の前記車載カメラからの視差画像の処理による対象物との距離情報を算出し、
前記ノイズ低減パラメータ決定部は、前記対象物との距離情報に応じて、複数の前記ノイズ低減フィルタのそれぞれのパラメータを補正することを特徴とする画像処理装置。 - 請求項5に記載の画像処理装置において、
前記ノイズ低減パラメータ決定部は、車速情報を用いて前記ノイズ低減フィルタのパラメータの補正タイミングを決定することを特徴とする画像処理装置。 - 外界情報を取得する車載カメラからの画像データを伝送線を介して入力し処理する画像処理方法であって、
前記伝送線に対するノイズ源としてあらかじめ登録された対象物が前記画像データに含まれるか否かを判定し、
前記画像データに前記ノイズ源が含まれる場合に、あらかじめ登録された前記ノイズ源の周波数またはノイズレベルに応じて、前記伝送線でのノイズを低減するノイズ低減フィルタのパラメータを変更することを特徴とする画像処理方法。 - 請求項8に記載の画像処理方法において、
前記車載カメラおよび伝送線は複数であって、
複数の前記車載カメラからの視差画像の処理による対象物との距離情報を算出し、
前記画像データに前記ノイズ源が含まれる場合に、前記対象物との距離情報に応じて、複数の前記伝送線からのそれぞれの画像データのノイズを低減する複数の前記ノイズ低減フィルタのそれぞれのパラメータを補正することを特徴とする画像処理方法。 - 請求項8に記載の画像処理方法において、
前記画像データに前記ノイズ源が含まれる場合に、車速情報を用いて前記ノイズ低減フィルタのパラメータの補正タイミングを決定することを特徴とする画像処理方法。
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023531363A JP7614352B2 (ja) | 2021-07-02 | 2022-02-02 | 画像処理システム、画像処理装置、及び画像処理方法 |
| DE112022002245.0T DE112022002245T5 (de) | 2021-07-02 | 2022-02-02 | Bildverarbeitungssystem, bildverarbeitungsvorrichtung und bildverarbeitungsverfahren |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-110584 | 2021-07-02 | ||
| JP2021110584 | 2021-07-02 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023276221A1 true WO2023276221A1 (ja) | 2023-01-05 |
Family
ID=84691063
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/004035 Ceased WO2023276221A1 (ja) | 2021-07-02 | 2022-02-02 | 画像処理システム、画像処理装置、及び画像処理方法 |
Country Status (3)
| Country | Link |
|---|---|
| JP (1) | JP7614352B2 (ja) |
| DE (1) | DE112022002245T5 (ja) |
| WO (1) | WO2023276221A1 (ja) |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002351488A (ja) * | 2001-05-28 | 2002-12-06 | Matsushita Electric Ind Co Ltd | ノイズキャンセル装置および車載システム |
| JP2009194438A (ja) * | 2008-02-12 | 2009-08-27 | Canon Inc | ノイズ低減装置及び撮像装置 |
| JP2010074899A (ja) * | 2008-09-17 | 2010-04-02 | Meidensha Corp | 画像処理によるパンタグラフの水平加速度測定装置および測定方法 |
| JP2011050582A (ja) * | 2009-09-02 | 2011-03-17 | Hitachi Medical Corp | 手術室ノイズ低減化システム |
| WO2012099190A1 (ja) * | 2011-01-21 | 2012-07-26 | 株式会社 日立ハイテクノロジーズ | 荷電粒子線装置、及び画像解析装置 |
| JP2020016838A (ja) * | 2018-07-27 | 2020-01-30 | 株式会社Jvcケンウッド | ノイズ低減装置、ノイズ低減方法およびノイズ低減プログラム |
| WO2020100529A1 (ja) * | 2018-11-14 | 2020-05-22 | オムロン株式会社 | 情報処理装置および情報処理装置の制御方法 |
Family Cites Families (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP5433610B2 (ja) | 2011-03-04 | 2014-03-05 | 日立オートモティブシステムズ株式会社 | 車載カメラ装置 |
-
2022
- 2022-02-02 WO PCT/JP2022/004035 patent/WO2023276221A1/ja not_active Ceased
- 2022-02-02 DE DE112022002245.0T patent/DE112022002245T5/de active Pending
- 2022-02-02 JP JP2023531363A patent/JP7614352B2/ja active Active
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002351488A (ja) * | 2001-05-28 | 2002-12-06 | Matsushita Electric Ind Co Ltd | ノイズキャンセル装置および車載システム |
| JP2009194438A (ja) * | 2008-02-12 | 2009-08-27 | Canon Inc | ノイズ低減装置及び撮像装置 |
| JP2010074899A (ja) * | 2008-09-17 | 2010-04-02 | Meidensha Corp | 画像処理によるパンタグラフの水平加速度測定装置および測定方法 |
| JP2011050582A (ja) * | 2009-09-02 | 2011-03-17 | Hitachi Medical Corp | 手術室ノイズ低減化システム |
| WO2012099190A1 (ja) * | 2011-01-21 | 2012-07-26 | 株式会社 日立ハイテクノロジーズ | 荷電粒子線装置、及び画像解析装置 |
| JP2020016838A (ja) * | 2018-07-27 | 2020-01-30 | 株式会社Jvcケンウッド | ノイズ低減装置、ノイズ低減方法およびノイズ低減プログラム |
| WO2020100529A1 (ja) * | 2018-11-14 | 2020-05-22 | オムロン株式会社 | 情報処理装置および情報処理装置の制御方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2023276221A1 (ja) | 2023-01-05 |
| JP7614352B2 (ja) | 2025-01-15 |
| DE112022002245T5 (de) | 2024-03-14 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN107810506B (zh) | 具有隐私保护的远程查看系统 | |
| US12231235B2 (en) | Communication device, communication method, and program | |
| CN111183707A (zh) | 无线通信装置 | |
| US20130329017A1 (en) | Vehicle-mounted camera device | |
| US20120290753A1 (en) | Connection method for bus controllers and communication system | |
| EP3984823A1 (en) | Side camera for vehicle and method of controlling the same | |
| US9136945B2 (en) | Vehicle communication system for visible light communication and optical networking and communication method thereof | |
| US20220060282A1 (en) | Communication apparatus and communication method, and program | |
| US11818494B2 (en) | Automobile camera comprising raw image signal interface | |
| US20160014105A1 (en) | Out-of-vehicle device interface apparatus and method for protecting in-vehicle network | |
| US8896691B2 (en) | Surveillance device and method | |
| EP4333333A1 (en) | Transmitter, receiver, parameter adjustment method, serdes circuit and electronic device | |
| JP7614352B2 (ja) | 画像処理システム、画像処理装置、及び画像処理方法 | |
| CN115339404B (zh) | 车载通信系统、车辆及车载通信处理方法 | |
| KR20190128153A (ko) | 통신 장치 및 통신 시스템 | |
| WO2018025607A1 (ja) | 車載カメラ装置、車載カメラ調整装置及び車載カメラ調整システム | |
| US11356656B2 (en) | Signal processing device, signal processing method, and signal processing system | |
| JP2006333007A (ja) | 車両通信システム及びデータ通信方法 | |
| JP7122547B2 (ja) | 映像処理装置および映像処理システム | |
| US12149366B2 (en) | Communication device and communication system for retransmission control | |
| JP7464801B2 (ja) | 画像処理装置、および、画像データ送信方法 | |
| KR101512641B1 (ko) | 가시광 통신 및 광 네트워킹이 가능한 차량용 통신 시스템 및 방법 | |
| KR102158830B1 (ko) | 충돌사고 예방 장치 및 방법 | |
| US11669484B2 (en) | Image sensor | |
| WO2018192585A1 (zh) | 传输方法和传输装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22832389 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023531363 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 112022002245 Country of ref document: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 22832389 Country of ref document: EP Kind code of ref document: A1 |