WO2022019315A1 - 潤滑状態推定装置及び方法、滑り軸受装置、機械装置、並びに旋動式破砕機 - Google Patents
潤滑状態推定装置及び方法、滑り軸受装置、機械装置、並びに旋動式破砕機 Download PDFInfo
- Publication number
- WO2022019315A1 WO2022019315A1 PCT/JP2021/027231 JP2021027231W WO2022019315A1 WO 2022019315 A1 WO2022019315 A1 WO 2022019315A1 JP 2021027231 W JP2021027231 W JP 2021027231W WO 2022019315 A1 WO2022019315 A1 WO 2022019315A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- index
- lubrication
- lubrication state
- bearing
- sliding surface
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B02—CRUSHING, PULVERISING, OR DISINTEGRATING; PREPARATORY TREATMENT OF GRAIN FOR MILLING
- B02C—CRUSHING, PULVERISING, OR DISINTEGRATING IN GENERAL; MILLING GRAIN
- B02C2/00—Crushing or disintegrating by gyratory or cone crushers
- B02C2/02—Crushing or disintegrating by gyratory or cone crushers eccentrically moved
- B02C2/04—Crushing or disintegrating by gyratory or cone crushers eccentrically moved with vertical axis
- B02C2/06—Crushing or disintegrating by gyratory or cone crushers eccentrically moved with vertical axis and with top bearing
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16C—SHAFTS; FLEXIBLE SHAFTS; ELEMENTS OR CRANKSHAFT MECHANISMS; ROTARY BODIES OTHER THAN GEARING ELEMENTS; BEARINGS
- F16C17/00—Sliding-contact bearings for exclusively rotary movement
- F16C17/12—Sliding-contact bearings for exclusively rotary movement characterised by features not related to the direction of the load
- F16C17/24—Sliding-contact bearings for exclusively rotary movement characterised by features not related to the direction of the load with devices affected by abnormal or undesired positions, e.g. for preventing overheating, for safety
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16N—LUBRICATING
- F16N29/00—Special means in lubricating arrangements or systems providing for the indication or detection of undesired conditions; Use of devices responsive to conditions in lubricating arrangements or systems
- F16N29/04—Special means in lubricating arrangements or systems providing for the indication or detection of undesired conditions; Use of devices responsive to conditions in lubricating arrangements or systems enabling a warning to be given; enabling moving parts to be stopped
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01M—TESTING STATIC OR DYNAMIC BALANCE OF MACHINES OR STRUCTURES; TESTING OF STRUCTURES OR APPARATUS, NOT OTHERWISE PROVIDED FOR
- G01M13/00—Testing of machine parts
- G01M13/04—Bearings
Definitions
- the present disclosure relates to a technique for estimating the lubrication state of the sliding surfaces of two relative moving objects.
- Patent Documents 1 and 2 propose a technique for preventing abnormal wear and seizure in a bearing device.
- Patent Document 1 in a slide bearing composed of a bearing metal on which a lubricating film is formed and a bearing support portion that holds the bearing metal, a temperature sensor detects the temperature around the bearing metal, and the temperature rise is based on the temperature rise. It is disclosed to know the poor lubrication.
- Patent Document 2 describes shaft vibration by an overcurrent type sensor, bearing box vibration by a piezoelectric type acceleration sensor, and a rotating shaft as a method for determining the presence or absence of rubbing (contact between a rotating part and a stationary part) in a slide bearing or the like. It is disclosed that an acoustic signal or the like generated when the bearing comes into contact with the bearing is used. Further, in Patent Document 2, the waveform data representing the acceleration of vibration generated during the operation of the sliding bearing and the axial rotation cycle of the sliding bearing are detected, and the acceleration waveform data is Fourier transformed to obtain the acceleration spectrum in the frequency domain. It is disclosed that the presence or absence of an abnormality in a sliding bearing is determined based on waveform data obtained by cepstrum analysis of an acceleration spectrum.
- the Stribeck curve is used to explain the lubrication state between two surfaces having relative motion.
- the Stribeck curve exemplified in FIG. 1 shows the friction coefficient f, the viscosity ⁇ of the lubricating film, the sliding speed v of the sliding surface, and the pressing load of the sliding surface on the sliding surfaces of two objects that move relative to each other.
- the relationship with the physical quantity S * (S * ⁇ v / F), which is a combination of the three elements of F, is shown.
- the Stribeck curve shows how the characteristics of the friction coefficient change as the lubrication state changes from fluid lubrication to boundary lubrication through mixed lubrication.
- a lubricating film that is sufficiently thicker than the surface roughness is interposed between the sliding surfaces, and the sliding surfaces are completely separated by a continuous lubricating film.
- the lubricating film becomes thinner than fluid lubrication, and the convex portions of the sliding surface come into local contact with each other.
- boundary lubrication the lubricating film is thinner than that in mixed lubrication, and the convex portions of the sliding surfaces are brought into contact with each other via the molecular level lubricating film.
- the present disclosure has been made in view of the above circumstances, and the purpose of the present disclosure is to estimate the lubrication state of the sliding surfaces of two objects that move relative to each other, thereby preventing seizure of the sliding surfaces. There is something in it.
- the inventors of the present application have determined the positive and negative of the time change rate of the friction coefficient f of the sliding surface and the time change rate of the physical quantity S * after the lubrication state changes from fluid lubrication to mixed lubrication and before the transition to boundary lubrication.
- the lubrication state estimation device is a lubrication state estimation device that estimates the lubrication state of the sliding surfaces of two objects that move relative to each other.
- It comprises at least one memory in which a program executed by the processor is stored.
- the friction coefficient of the sliding surface or an index that correlates with the friction coefficient is used as the first index.
- S * ⁇ v / F (where ⁇ is the viscosity of the lubricant intervening in the sliding surface, v is the sliding speed of the sliding surface, and F is the pressing load of the sliding surface) .
- the index that correlates with the physical quantity S * is used as the second index.
- the processor acquires the first index and the second index, and based on the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index, the sliding surface of the sliding surface. It estimates the lubrication state.
- the lubrication state estimation method is a lubrication state estimation method for estimating the lubrication state of the sliding surfaces of two objects having relative motions.
- F is a physical quantity S * or the physical quantity S * an index correlated with second indicator represented by pressing load) of the sliding surface, Acquiring the first index and the second index, and It includes estimating the lubrication state of the sliding surface based on the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index.
- the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index differs depending on whether the lubrication state of the sliding surface is fluid lubrication or mixed lubrication.
- fluid lubrication is performed based on the change in the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index.
- the lubrication state of the moving surface can be estimated. Then, by using this estimation result, it is possible to grasp the sign before the lubrication state shifts to the boundary lubrication and seizure or the like occurs. Then, by performing a process for preventing seizure or the like at the timing when a sign of seizure or the like is caught, seizure or the like can be prevented in advance.
- the above lubrication state estimation device and method it is sufficient to know the positive and negative of the time change rate for the first index and the second index, so that the exact values of the first index and the second index are not required. Therefore, according to the above-mentioned lubrication state estimation device and method, it is possible to estimate the lubrication state of the sliding surface of two objects having relative motion in an actual machine in which it is difficult to measure an exact value.
- the lubrication state estimation device is a lubrication state estimation device that estimates the lubrication state of the sliding surface between the rotating shaft and the bearing.
- It comprises at least one memory in which a program executed by the processor is stored.
- the shaft torque of the rotating shaft or an index that correlates with the shaft torque is used as the third index
- the pressing load of the sliding surface or the index that correlates with the pressing load is used as the fourth index.
- the processor acquires the third index and the fourth index, and plots the acquired third index and the fourth index on a chart in which the vertical axis represents the third index and the horizontal axis represents the fourth index.
- the lubrication state estimation method is a lubrication state estimation method for estimating the lubrication state of the sliding surface between the rotating shaft and the bearing, and is the shaft torque of the rotating shaft or the shaft.
- the index that correlates with the torque is used as the third index
- the pressing load on the sliding surface or the index that correlates with the pressing load is used as the fourth index
- the third index and the fourth index are acquired
- the vertical axis is used.
- the slope of the tangent line of the TF line is substantially constant or decreases as the pressing load F increases, and the intercept of the tangent line of the TF line is 0 or a positive value.
- the slope of the tangent line of the TF line increases as the pressing load F increases (that is, the ratio of boundary lubrication in the mixed lubrication increases), and the intercept of the tangent line of the TF line becomes 0 or negative. It is known to be the value of.
- the lubrication state of the sliding surface is estimated based on the inclination of the tangent line of the TF line and the section of the tangent line, and before seizure occurs. You can catch the sign. Then, by performing a process for preventing seizure or the like at the timing when a sign of seizure or the like is caught, seizure or the like can be prevented in advance.
- the above-mentioned lubrication state estimation device and method it is sufficient to know the positive / negative of the slope of the tangent of the TF line and the positive / negative of the intercept of the tangent of the TF line. No value is required. Therefore, according to the above-mentioned lubrication state estimation device and method, it is possible to estimate the lubrication state of the sliding surface between the rotating shaft and the bearing in an actual machine in which it is difficult to measure an exact value.
- the rotary crusher is a rotary crusher. Concave and With the spindle placed inside the concave, The mantle provided on the spindle and An eccentric sleeve in which the lower part of the spindle is rotatably inserted, With the boss into which the eccentric sleeve is rotatably inserted, A drive shaft that rotationally drives the eccentric sleeve, A drive motor that rotates and drives the drive shaft, A hydraulic cylinder that supports the spindle so that it can be raised and lowered, A first fluid lubricated bearing formed between the spindle and the eccentric sleeve, A second fluid lubricated bearing formed between the eccentric sleeve and the boss, Boundary lubrication bearings formed between the spindle and the hydraulic cylinder, A function that correlates with ⁇ the shaft power of the drive shaft or an index that correlates with the shaft power / the cylinder pressure of the hydraulic cylinder or the index that correlates with the cylinder pressure ⁇ is
- a function that correlates with ⁇ 1 / the cylinder pressure or an index that correlates with the cylinder pressure ⁇ is used as the sixth index, and at least one sixth index measuring instrument that measures the sixth index. It is provided with a lubrication state estimation device that estimates the lubrication state of the first fluid lubrication bearing, the second fluid lubrication bearing, and the boundary lubrication bearing based on the rate of change of the fifth index with respect to the sixth index.
- a concave, a main shaft arranged inside the concave, a mantle provided on the main shaft, and a lower portion of the main shaft are rotatable.
- the inserted eccentric sleeve, the boss into which the eccentric sleeve is rotatably inserted, the drive shaft for rotationally driving the eccentric sleeve, the drive motor for rotationally driving the drive shaft, and the spindle are movably supported.
- the function that correlates with ⁇ the shaft power of the drive shaft or the index that correlates with the shaft power / the cylinder pressure of the hydraulic cylinder or the index that correlates with the cylinder pressure ⁇ is used as the fifth index.
- the function that correlates with ⁇ 1 / the cylinder pressure or the index that correlates with the cylinder pressure ⁇ is used as the sixth index.
- Lubrication of the first fluid lubricated bearing, the second fluid lubricated bearing, and the boundary lubricated bearing based on the acquisition of the fifth index and the sixth index and the rate of change of the fifth index with respect to the sixth index. It involves estimating the state.
- the lubrication state of the fluid lubrication bearing and the boundary lubrication bearing can be estimated individually by one device, and thereby it is possible to estimate where the seizure sign is occurring. ..
- the lubrication state of the fluid lubrication bearing and the boundary lubrication bearing is estimated individually in a series of processes, and thereby, where the seizure sign is generated is estimated. be able to. That is, it is not necessary to individually estimate the lubrication state of the fluid-lubricated bearing and the boundary-lubricated bearing.
- FIG. 1 is a Stribeck diagram.
- FIG. 2 is a diagram showing a journal slide bearing model used in Verification 1.
- FIG. 3 is a chart showing the results of verification 1.
- FIG. 4 is a diagram showing a thrust slide bearing model used in verification 2.
- FIG. 5A is a chart showing the results of the simulation of verification 2.
- FIG. 5B is a chart showing the results of the element test of verification 2.
- FIG. 6 is a block diagram showing a schematic configuration of the lubrication state estimation system according to the first embodiment of the present disclosure.
- FIG. 7 is a flowchart illustrating a processing flow of the lubrication state estimation device.
- FIG. 8 is a flowchart illustrating a modified example of the processing flow of the lubrication state estimation device.
- FIG. 7 is a flowchart illustrating a processing flow of the lubrication state estimation device.
- FIG. 9 is a conversion of the Stribeck diagram shown in FIG. 1 into a TF diagram.
- FIG. 10 is a chart showing the results of verification 3.
- FIG. 11 is a chart showing the change in the slope of the tangent line of the curve drawn in the chart of FIG.
- FIG. 12 is a chart showing changes in the values of the sections of the curves drawn in the chart of FIG.
- FIG. 13 is a block diagram showing a schematic configuration of the lubrication state estimation system according to the second embodiment of the present disclosure.
- FIG. 14 is a flowchart illustrating a processing flow of the lubrication state estimation device.
- FIG. 15 is a third index-4th index diagram in which the third index and the fourth index are plotted.
- FIG. 16 is a diagram showing a plain bearing device including a lubrication state estimation system.
- FIG. 17 is a diagram showing a mechanical device including a lubrication state estimation system.
- FIG. 18 is a diagram showing a schematic configuration of a rotary crusher used in an actual machine simulated test.
- FIG. 19 is a chart showing the results of an actual machine mock test.
- FIG. 20A is a 5th index-6th index diagram of the lower bearing.
- FIG. 20B is a 5th index-6th index diagram of the spindle thrust bearing.
- FIG. 21 is a block diagram showing a schematic configuration of the lubrication state estimation system according to the third embodiment of the present disclosure.
- FIG. 22 is a flowchart illustrating a processing flow of the lubrication state estimation device.
- the sliding conditions of the sliding surface change with the passage of time. For example, it is assumed that the load F applied to the sliding surface increases, the sliding speed v of the sliding surface decreases, or the viscosity ⁇ of the lubricant decreases with the passage of time.
- the physical quantity S * gradually decreases with time as the sliding conditions. That is, if the rate of change of the physical quantity S * with the change of the sliding condition is negative, the lubrication state of the sliding surface advances on the Stribeck curve toward the left side of the chart with the passage of time.
- the time change rate of the physical quantity S * is negative (decrease)
- the time change rate of the friction coefficient f is negative (decrease).
- Such matching between the positive and negative of the time change rate of the friction coefficient f and the positive and negative of the time change rate of the physical quantity S * is hereinafter referred to as "positive correlation”.
- the time change rate of the physical quantity S * is negative (decrease)
- the time change rate of the friction coefficient f is positive (increase).
- Such a positive / negative of the time change rate of the friction coefficient f and a positive / negative of the time change rate of the physical quantity S * are hereinafter referred to as “negative correlation”.
- Table 1 shows the correlation between the positive / negative of the time change rate of the friction coefficient f and the positive / negative of the time change rate of the physical quantity S * (hereinafter, simply referred to as “correlation between the friction coefficient f and the physical quantity S *”).
- the friction coefficient f may be replaced with the first index (friction coefficient f or an index correlating with the friction coefficient), and the physical quantity S * may be replaced with the second index (physical quantity S * or an index correlating with the S *).
- the change in the lubrication state of the sliding surface can be similarly detected from the change in the correlation between these two indexes.
- the correlation of the "correlation index” may be either a positive correlation or a negative correlation.
- Tables 2 to 5 show the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index (hereinafter, simply referred to as "correlation between the first index and the second index"). ..
- the first index may be the friction coefficient f and the second index may be the physical quantity S * .
- Table 3 is applicable, for example, when the first index is the friction coefficient f and the second index is ⁇ 1 / physical quantity S * ⁇ .
- Table 4 applies, for example, to the case where the first index is ⁇ 1 / friction coefficient f ⁇ and the second index is the physical quantity S *.
- Table 5 is applicable, for example, when the first index is ⁇ 1 / friction coefficient f ⁇ and the second index is ⁇ 1 / physical quantity S * ⁇ .
- FIG. 2 is a diagram showing a journal plain bearing model used in the simulation of verification 1.
- a rotating shaft 41 is inserted into the journal sliding bearing 42, and a lubricating film 43 made of a lubricant is formed between the inner circumference of the journal sliding bearing 42 and the outer periphery of the rotating shaft 41.
- the rotary shaft 41 is rotated under the condition that the rotational speed of the rotary shaft 41 is constant and the viscosity ⁇ of the lubricant decreases with time as the temperature of the lubricant rises. Further, the friction coefficient f and the change with time of the bearing load when the pressing load F on the bearing was changed with time were obtained by simulation.
- the rotation speed of the rotating shaft 41 is a physical quantity corresponding to the sliding speed v of the sliding surface
- the bearing load is a physical quantity corresponding to the pressing load F of the sliding surface.
- the correlation between the positive and negative of the time change rate of the friction coefficient f and the positive and negative of the time change rate of the pressing load F (hereinafter, simply referred to as "correlation between the friction coefficient f and the pressing load F") is negative. Show the correlation.
- the pressing load F and the friction coefficient f fluctuate periodically under mixed lubrication, and the cycles are equal and have the same phase. More specifically, under mixed lubrication, the friction coefficient f increases while the pressing load F increases, and the friction coefficient f decreases while the pressing load F decreases. That is, under mixed lubrication, the correlation between the friction coefficient f and the pressing load F shows a positive correlation.
- the first index (friction coefficient f) is the second index with respect to the time change rate.
- Relative ratio of the time change rate of the second index time change rate of the second index / time change rate of the first index
- the relative ratio of the amplitude of the second index to the amplitude of the first index amplitude of the second index / the first index.
- the relative ratio of the time change rate of the second index to the time change rate of the first index, and The relative ratio of the amplitude of the second index to the amplitude of the first index changes in the increasing direction. Further, as the ratio of boundary lubrication increases, the relative ratio of the time change rate of the second index to the time change rate of the first index and the relative ratio of the amplitude of the second index to the amplitude of the first index become smaller again. It changes in the direction of becoming.
- FIG. 4 is a diagram showing a thrust slide bearing model used in the element test and simulation of verification 2.
- a lubricating film 46 made of a lubricant is formed between a thrust bearing 45 and a rotating disk 44 supported by the thrust bearing 45.
- the rotational speed of the rotating disk 44 is kept constant
- the viscosity ⁇ of the lubricant is kept constant by temperature control
- the pressing load F on the bearing is changed periodically while increasing. The changes over time in the friction coefficient f and the pressing load F at the time were obtained.
- the rotation speed of the rotating disk 44 is a physical quantity corresponding to the sliding speed v of the sliding surface
- the bearing load is a physical quantity corresponding to the pressing load F of the sliding surface.
- the chart (simulation result) of FIG. 5A shows the change over time in the pressing load F (bearing load) on the sliding surface and the change over time in the friction coefficient f. From this chart, it can be read that the pressing load F and the friction coefficient f fluctuate periodically under fluid lubrication, the periods are equal, and the phase difference is half a period. More specifically, under fluid lubrication, the coefficient of friction f decreases while the pressing load F increases, and the coefficient of friction increases while the pressing load F decreases. That is, under fluid lubrication, the correlation between the friction coefficient f and the pressing load F shows a negative correlation.
- the pressing load F and the friction coefficient f fluctuate periodically under mixed lubrication, and the cycles are equal and have the same phase. More specifically, under mixed lubrication, the friction coefficient f increases while the pressing load F increases, and the friction coefficient f decreases while the pressing load F decreases. That is, under mixed lubrication, the correlation between the friction coefficient f and the pressing load F shows a positive correlation.
- FIG. 5B is a chart of the results of the element test. Similar to the simulation result of FIG. 5A, it was confirmed that the correlation between the friction coefficient f and the pressing load F was established in the element test. In the element test, there are no sliding marks (wear marks) on the sliding surface in fluid lubrication, and in the test conditions where the pressing load F is increased until mixed lubrication, the sliding marks (wear) remaining on the sliding surface. By confirming the marks), the actual sliding state was judged, and the validity of the simulation was confirmed.
- the first index (friction coefficient f) is the second index with respect to the time change rate.
- the relative ratio of the time change rate of (pressing load F) and the relative ratio of the amplitude of the second index to the amplitude of the first index change in a smaller direction.
- the relative ratio of the time change rate of the second index to the time change rate of the first index, and The relative ratio of the amplitude of the second index to the amplitude of the first index changes in the increasing direction.
- the relative ratio of the time change rate of the second index to the time change rate of the first index and the relative ratio of the amplitude of the second index to the amplitude of the first index can be estimated, and the ratio of boundary lubrication to mixed lubrication can be estimated under mixed lubrication.
- the lubrication state of the sliding surface is estimated based on whether the correlation between the friction coefficient f and the physical quantity S * is a positive correlation or a negative correlation. However, it is regarded as a sign of seizure of the sliding surface.
- Lubrication state estimation may include estimation of fluid lubrication or mixed lubrication. To estimate the lubrication state, it is estimated that the lubrication state has changed from fluid lubrication to mixed lubrication based on the change in the correlation between the friction coefficient f and the physical quantity S * from a positive correlation to a negative correlation. May be included.
- the estimation of the lubrication state may include estimating the degree of fluid lubrication and mixed lubrication.
- FIG. 6 is a block diagram showing a schematic configuration of the lubrication state estimation system 50 according to the first embodiment of the present disclosure.
- the lubrication state estimation system 50 shown in FIG. 6 includes an index measuring device 51 including a first index measuring device 51a for measuring the first index and a second index measuring device 51b for measuring the second index, and a lubrication state estimating device 53. including.
- the index measuring device 51 includes at least one type of measuring device for measuring the first index, the second index, or the physical quantity which is a component thereof.
- the first index measuring instrument 51a and the second index measuring instrument 51b may include a common measuring instrument.
- the first index measuring instrument 51a and the second index measuring instrument 51b are appropriately selected from various instruments according to the physical quantity to be measured.
- the first index is an index that correlates with the friction coefficient f or the friction coefficient f of the sliding surfaces of two objects that make relative motion.
- the "index that correlates with the friction coefficient f" is an index that corresponds to the positive and negative of the friction coefficient f and the time change rate.
- the positive and negative of the time change rate correspond includes the case where the positive and negative of the time change rate match and the case where the positive and negative of the time change rate are opposite.
- the first index may be an index composed of one kind of physical quantity or an index composed of a combination of two or more kinds of physical quantities. As the first index, it is sufficient to know the positive or negative of the time change rate, so a quantitative and accurate value is not required.
- the second index is the physical quantity of the sliding surfaces of the two objects to the relative movement S *, or is an index correlated with the physical quantity S *.
- the "index that correlates with the physical quantity S * " is an index in which the positive and negative of the physical quantity S * and the time change rate correspond to each other.
- the components of the second index include the viscosity ⁇ of the lubricant intervening in the sliding surface, the sliding speed v of the sliding surface, the pressing load F of the sliding surface, or the physical quantity correlating with them. good.
- the second index it is sufficient to know the positive or negative of the time change rate, so a quantitative and accurate value is not required. Therefore, the viscosity ⁇ of the lubricant may be replaced by the temperature of the lubricant, or the sliding speed v of the sliding surface may be replaced by the rotation speed.
- the lubrication state estimation device 53 is a so-called computer, and includes at least one processor and at least one memory in which a program executed by the processor is stored. In addition to the program executed by the processor, various fixed data and the like are stored in the memory.
- the processor sends and receives data to and from an external device.
- the processor reads and executes software such as a program stored in the memory, so that the process described later is performed.
- the lubrication state estimation device 53 may execute each process by centralized control by a single computer, or may execute each process by the cooperation of a plurality of computers.
- FIG. 7 is a flowchart illustrating a processing flow of the lubrication state estimation device 53.
- the lubrication state estimation device 53 acquires the first index and the second index from the index measuring device 51 (step S1). Then, the lubrication state estimation device 53 determines the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index (hereinafter, simply referred to as "correlation between the first index and the second index"). Obtain (step S2).
- the lubrication state estimation device 53 determines whether the lubrication state of the sliding surface is fluid lubrication or mixed lubrication based on whether the correlation between the first index and the second index is a positive correlation or a negative correlation (step). S3).
- the lubrication state estimation device 53 estimates the degree of fluid lubrication. Specifically, the lubrication state estimation device 53 relates to the relative ratio of the time change rate of the second index to the time change rate of the first index, and the amplitude of the first index when the second index changes periodically. At least one of the relative ratios of the amplitudes of the second index is obtained (step S4). The lubrication state estimation device 53 evaluates the soundness of fluid lubrication based on the obtained relative ratio (step S5).
- the lubrication state estimation device 53 estimates the lubrication film thickness based on the obtained relative ratio, compares the estimated lubrication film thickness with a predetermined threshold value, and if the lubrication film thickness is equal to or greater than the threshold value. Evaluate that the fluid lubrication is sound. Information for specifying the relationship between the relative ratio and the lubrication film thickness is stored in advance in the lubrication state estimation device 53, and the lubrication state estimation device 53 can estimate the lubrication film thickness from the relative ratio using this information. .. Further, the threshold value regarding the lubrication film thickness may be appropriately set according to the sliding surface.
- step S5 If the fluid lubrication is sound (YES in step S5), the process returns to S1 and is repeated. If the fluid lubrication is not sound (NO in step S5), the lubrication state estimation device 53 outputs a warning from the connected alarm device (not shown) (step S6), and returns the process to step S1. It should be noted that this warning does not notify the detection of a sign of seizure, but merely notifies that the thickness of the lubricating film forming the fluid lubrication is decreasing (approaching mixed lubrication). However, the worker can receive the warning and take appropriate measures.
- the lubrication state estimation device 53 estimates the degree of mixed lubrication. Specifically, the lubrication state estimation device 53 relates to the relative ratio of the time change rate of the second index to the time change rate of the first index, and the amplitude of the first index when the second index changes periodically. At least one of the relative ratios of the amplitudes of the second index is obtained (step S11). Then, the lubrication state estimation device 53 determines whether or not the seizure risk is low based on the obtained relative ratio (step S12).
- the lubrication state estimation device 53 estimates the ratio of boundary lubrication to the mixed lubrication based on the obtained relative ratio, compares the ratio of boundary lubrication with a predetermined threshold value, and the ratio of boundary lubrication is the threshold value. If it is larger, it is judged that the seizure risk is high, and if the boundary lubrication ratio is below the threshold, it is judged that the seizure risk is low.
- Information for specifying the relationship between the relative ratio and the ratio of boundary lubrication to mixed lubrication is stored in advance in the lubrication state estimation device 53, and the lubrication state estimation device 53 uses this information to calculate the ratio of boundary lubrication from the relative ratio. Can be estimated.
- the threshold value regarding the ratio of boundary lubrication is a value at which seizure does not occur and a value that can secure a sufficient time until seizure occurs is appropriately set according to the sliding surface. It's okay.
- the threshold value regarding the ratio of boundary lubrication in this way, the sign of seizure is not detected in the light mixed lubrication, and misdiagnosis can be avoided.
- light mixed lubrication has sufficient margin for seizure, and it may not be necessary to take immediate action. Therefore, by setting the threshold value in consideration of the operating condition of two objects including the sliding surface (for example, shaft and bearing) and the influence when damage occurs, processing to prevent seizure etc. is performed. It is possible to determine when to start.
- the lubrication state estimation device 53 determines that the seizure risk is low (YES in step S12), it outputs a warning from the connected alarm device (not shown) (step S13), and returns the process to step S1. It should be noted that this warning does not notify the detection of a sign of seizure, but merely notifies that the lubrication state is mixed lubrication, but the operator may receive the warning and take appropriate measures. can.
- the lubrication state estimation device 53 determines that the seizure risk is high (NO in step S12), it detects it as a sign of seizure (step S14) and outputs an alarm from the connected alarm device (not shown). (Step S15). This alarm notifies the detection of a sign of seizure. Further, the lubrication state estimation device 53 outputs a command signal for operating the machine to perform a predetermined process after detecting a sign of seizure, or displays and outputs the content of the process on a monitor (not shown). (Step S16), the process may be terminated.
- the predetermined treatment may include the addition of a lubricant, the reduction of the pressing load F, and the suspension of relative motion at least one of them.
- FIG. 8 is a flowchart illustrating a modified example of the processing flow of the lubrication state estimation device 53.
- step S4 and step S5 are omitted and it is determined in step S3 that fluid lubrication is performed, the process returns to S1 and is repeated.
- step S13 is omitted and it is determined in step S12 that the seizure risk is low, the process returns to S1 and is repeated, which is different from the process flow shown in FIG. 7. Due to these differences, the processing flow shown in FIG. 8 is simpler than the processing flow shown in FIG. 7, and the sign of seizure is detected only when the mixed lubrication is clearly in progress. Will be done.
- the lubrication state estimation device 53 includes at least one processor and at least one memory in which a program executed by the processor is stored, and the processor is a first index and a first index.
- the second index is acquired, and the sliding surface is based on the correlation between the first index and the second index (that is, the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index).
- the first index is an index that correlates with the friction coefficient f of the sliding surface or the friction coefficient f
- the viscosity of the agent v is the sliding speed of the sliding surface
- F is an index correlated with the physical quantity S * or the physical quantity S * represented by pressing load) of the sliding surface.
- the sliding surface is obtained based on the acquisition of the first index and the second index and the correlation between the first index and the second index. Includes estimating the lubrication state of.
- the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index differs depending on whether the lubrication state of the sliding surface is fluid lubrication or mixed lubrication.
- the lubrication state of the sliding surface is determined based on the correlation between the positive / negative of the time change rate of the first index and the positive / negative of the time change rate of the second index. Whether it is fluid lubrication or mixed lubrication, and its transition can be estimated. Then, by using this estimation result, it is possible to catch the sign before seizure or the like occurs. Then, by performing a process for preventing seizure or the like at the timing when a sign of seizure or the like is caught, seizure or the like can be prevented in advance.
- the lubrication state estimation device 53 and the method it is sufficient to know the positive and negative of the time change rate for the first index and the second index, so that the exact values of the first index and the second index are not required. Therefore, according to the lubrication state estimation device 53 and the method, it is possible to estimate the lubrication state of the sliding surface of two objects having relative motion in an actual machine in which it is difficult to measure an exact value.
- the processor estimates that the sliding surface is fluid lubrication
- the relative ratio of the time change rate of the second index to the time change rate of the first index the relative ratio of the time change rate of the second index to the time change rate of the first index
- the soundness of the fluid lubrication of the sliding surface is evaluated based on at least one of the relative ratios of the amplitude of the second index to the amplitude of the first index when the second index changes periodically.
- the processor estimates that the sliding surface is mixed lubrication
- the relative ratio of the time change rate of the second index to the time change rate of the first index is estimated based on at least one of the relative ratios of the amplitude of the second index to the amplitude of the first index when the second index changes periodically.
- the relative ratio of the time change rate of the second index to the time change rate of the first index when the sliding surface is estimated to be fluid lubrication under mixed lubrication, the relative ratio of the time change rate of the second index to the time change rate of the first index.
- the integrity of fluid lubrication of sliding surfaces based on at least one of the relative ratios of the amplitude of the second index to the amplitude of the first index when the second index changes periodically.
- the relative ratio of the time change rate of the second index to the time change rate of the first index and the second index when the sliding surface is estimated to be mixed lubrication, the relative ratio of the time change rate of the second index to the time change rate of the first index and the second index. Further includes estimating the ratio of boundary lubrication to the mixed lubrication of the sliding surface based on at least one of the relative ratios of the amplitude of the second index to the amplitude of the first index when the number changes periodically.
- the soundness of (thickness) can be evaluated, and the ratio of boundary lubrication to mixed lubrication can be estimated under mixed lubrication. Therefore, by estimating the soundness of the fluid lubrication of the sliding surface and the ratio of the boundary lubrication to the mixed lubrication based on the above relative ratio, the operation of two objects including the sliding surface (for example, a shaft and a bearing) can be operated. It is possible to determine the timing to start the process for preventing seizure, etc., in consideration of the condition and the influence when damage occurs.
- FIG. 9 is a conversion of the Stribeck diagram shown in FIG. 1 into a TF diagram under conditions where the viscosity ⁇ and the sliding speed v are constant.
- the vertical axis represents the shaft torque T
- the horizontal axis represents the pressing load F.
- a TF line showing the relationship between the shaft torque T and the pressing load F is drawn.
- the slope of the tangent line of the TF line decreases or is almost constant with increasing pressing load F (see FIGS. 9 and 7), and the intercept of the tangent line of the TF line. Is 0 or a positive value and increases as the pressing load F increases.
- the slope of the tangent to the TF line increases and the intercept decreases from positive to negative.
- the slope of the tangent line of the TF line increases as the pressing load F increases (that is, the ratio of boundary lubrication in the mixed lubrication increases), and the intercept of the tangent line of the TF line becomes negative. It is a value of and decreases as the pressing load F increases.
- the thickness of the lubricating film decreases as the pressing load F increases.
- the ratio of boundary lubrication in mixed lubrication increases as the pressing load F increases.
- Table 7 The characteristics of such TF lines are shown in Table 7 below.
- FIG. 11 is a chart showing the change in the inclination of the tangent line of the line (T'-F line) drawn in the chart of FIG. 10
- FIG. 12 is a chart showing the line (T'-F) drawn in the chart of FIG. It is a chart showing the change of the value of the intercept of the tangent line of the line).
- the T'-F line obtained in Verification 3 is consistent with the ideal TF line shown in FIG. That is, when the lubrication state is fluid lubrication, the slope of the tangent line of the T'-F line is generally constant or decreases with respect to the increase in the pressing load F, and the intercept of the tangent line of the T'-F line is 0 or positive. It is a value of and is constant or increases as the pressing load F increases.
- the slope of the tangent line of the T'-F line increases as the pressing load F increases, and the intercept of the tangent line of the T'-F line has a negative value and the pressing load F increases. It decreases remarkably according to. In this way, it was confirmed that the relationship between the index correlating with the shaft torque T (sliding drag force of the thrust bearing 45) and the pressing load F is also established in the element test.
- the lubrication state estimation system 50A estimates the lubrication state of the sliding surface between the rotating shaft and the bearing by utilizing the characteristics of the TF line as described above.
- the lubrication state estimation system 50A according to the present embodiment has at least one third index measuring instrument 51c for measuring the third index and at least one fourth index measuring device for measuring the fourth index. It is provided with an index measuring device 51 including the device 51d, and a lubrication state estimation device 53 that acquires a third index and a fourth index from the index measuring device 51 and estimates the lubrication state of the sliding surface using these.
- the third index measuring instrument 51c and the fourth index measuring instrument 51d are appropriately selected from various instruments according to the physical quantity to be measured.
- the third index measuring instrument 51c and the fourth index measuring instrument 51d may include a common measuring instrument.
- the third index T' is an index that correlates with the shaft torque T or the shaft torque T of the rotating shaft.
- the "index that correlates with the shaft torque T" is an index that corresponds to the positive and negative of the shaft torque T and the time change rate.
- the fourth index F' is an index that correlates with the pressing load F or the pressing load F on the sliding surface of the rotating shaft and the bearing.
- the "index that correlates with the pressing load F" is an index in which the positive and negative of the pressing load F and the time change rate correspond to each other.
- Indexes that correlate with the pressing load F include, for example, the control value of the pressing load (bearing load), the hydraulic value of the hydraulic equipment that receives the pressing load F, and the drive current value of the motor that gives rotational power to the drive shaft that drives the rotary shaft. and so on.
- the lubrication state estimation device 53 acquires the third index T'and the fourth index F'from the third index measuring device 51c and the fourth index measuring device 51d, and the vertical axis represents the third index T'and the horizontal axis represents the third index T'. Plot the acquired third index T'and fourth index F'on the T'-F'line diagram representing the fourth index F'is repeated at least twice, and the tangent line of the T'-F' line appearing in the chart. The slope of and the intercept of the tangent line are obtained. Then, the lubrication state estimation device 53 estimates the lubrication state of the sliding surface based on the combination of the inclination of the tangent line of the T'-F'line and the section of the tangent line.
- the soundness of the fluid lubrication may be evaluated when it is estimated to be fluid lubrication, or the ratio of boundary lubrication to the mixed lubrication may be estimated when it is estimated to be mixed lubrication.
- FIG. 14 is a flowchart illustrating a processing flow of the lubrication state estimation device 53.
- the lubrication state estimation device 53 acquires the third index and the fourth index (or their components) from the index measuring device 51 (step S21). Then, in the lubrication state estimation device 53, the measured value of the third index T'and the fourth index F'are shown in a log-log graph in which the vertical axis represents the third index T'and the horizontal axis represents the fourth index F'. Plot the measured values (step S22).
- a third index-fourth index line T'-F' line
- FIG. 15 shows an example of the third index-4th index diagram.
- the lubrication state estimation device 53 obtains the slope of the tangent line of the T'-F'line and the intercept of the tangent line (step S23). The lubrication state estimation device 53 determines whether or not the lubrication state of the sliding surface is fluid lubrication based on the combination of the inclination of the tangent line of the T'-F'line and the section of the tangent line (step S24). In order to determine whether or not the lubrication state of the sliding surface is fluid lubrication, the relationship between the T'-F'line and the lubrication state as shown in Table 7 stored in advance in the lubrication state estimation device 53 is used. Lubrication.
- the lubrication state estimation device 53 estimates the degree of fluid lubrication. Specifically, the lubrication state estimation device 53 evaluates the soundness of fluid lubrication based on the value of the section of the tangential line of the T'-F'line (step S25). Here, the lubrication state estimation device 53 estimates the lubrication film thickness from the value of the section of the tangent line, compares the estimated lubrication film thickness with a predetermined threshold value, and if the lubrication film thickness is equal to or more than the threshold value, fluid lubrication is performed. Is evaluated as healthy.
- Information for specifying the relationship between the value of the tangent section and the lubrication film thickness is stored in advance in the lubrication state estimation device 53, and the lubrication state estimation device 53 uses this information to obtain the lubrication film thickness from the value of the tangent section. Can be estimated. Further, the threshold value regarding the lubrication film thickness may be appropriately set according to the sliding surface.
- step S25 If the fluid lubrication is sound (YES in step S25), the process returns to S21 and is repeated. If the fluid lubrication is not sound (NO in step S25), the lubrication state estimation device 53 outputs a warning from the connected alarm device (not shown) (step S26), and returns the process to step S21. It should be noted that this warning does not notify the detection of a sign of seizure, but merely notifies that the thickness of the lubricating film forming the fluid lubrication has decreased, but the operator warns the warning. It can be received and appropriate measures can be taken as needed.
- the lubrication state estimation device 53 estimates the degree of mixed lubrication. Specifically, the lubrication state estimation device 53 determines whether or not the seizure risk is low based on the value of the tangential section of the TF line (step S27). Specifically, the lubrication state estimation device 53 estimates the ratio of boundary lubrication to the mixed lubrication based on the value of the section of the tangent line, compares the ratio of boundary lubrication with a predetermined threshold value, and determines the ratio of boundary lubrication.
- the threshold value When it is larger than the threshold value, it is judged that the seizure risk is high, and when the ratio of boundary lubrication is less than the threshold value, it is judged that the seizure risk is low.
- Information for specifying the relationship between the value of the tangent section and the ratio of boundary lubrication to the mixed lubrication is stored in advance in the lubrication state estimation device 53, and the lubrication state estimation device 53 uses this information to store the value of the tangent section.
- the ratio of boundary lubrication can be estimated from.
- the threshold value regarding the ratio of boundary lubrication is a value at which seizure does not occur and a value that can secure a sufficient time until seizure occurs is appropriately set according to the sliding surface. It's okay.
- the threshold value regarding the ratio of boundary lubrication By setting the threshold value regarding the ratio of boundary lubrication in this way, the sign of seizure is not detected in the light mixed lubrication, and misdiagnosis can be avoided. In addition, light mixed lubrication has sufficient margin for seizure, and it may not be necessary to take immediate action. Therefore, by setting the threshold value in consideration of the operating condition of two objects including the sliding surface (for example, shaft and bearing) and the influence when damage occurs, processing to prevent seizure etc. is performed. It is possible to determine when to start.
- the lubrication state estimation device 53 determines that the seizure risk is low (YES in step S27), it outputs a warning from the connected alarm device (not shown) (step S28), and returns the process to step S21. It should be noted that this warning does not notify the detection of a sign of seizure, but merely notifies that the lubrication state is mixed lubrication, but the operator may receive the warning and take appropriate measures. can.
- the lubrication state estimation device 53 determines that the seizure risk is high (NO in step S27), it detects this as a sign of seizure (step S29) and outputs an alarm from the connected alarm device (not shown). (Step S30). This alarm notifies the detection of a sign of seizure. Further, the lubrication state estimation device 53 outputs a command signal for operating the machine to perform a predetermined seizure prevention process after detecting a sign of seizure, or displays the content of the process on a monitor (not shown). It may be output (step S31).
- the predetermined treatment may include at least one of additional reduction of lubricant, reduction of pressing load F, and suspension of rotational motion.
- the lubrication state estimation device 53 estimates the lubrication state of the sliding surface between the rotating shaft and the bearing, and is executed by at least one processor and the processor.
- the third index T' is provided with at least one memory in which the program is stored, and the shaft torque of the rotating shaft or the index correlating with the shaft torque is set as the third index T', and the pushing load of the sliding surface or the index correlating with the pushing load is the third index.
- the processor acquires the 3rd index T'and the 4th index F', and the vertical axis represents the 3rd index T'and the horizontal axis represents the 4th index F'.
- Estimate the state To estimate the lubrication state, estimate whether it is fluid lubrication or mixed lubrication, evaluate the soundness of fluid lubrication when it is estimated to be fluid lubrication, and when it is estimated to be mixed lubrication. At least one of estimating the ratio of boundary lubrication to mixed lubrication may be included.
- the lubrication state estimation method is a lubrication state estimation method for estimating the lubrication state of the sliding surface between the rotating shaft and the bearing, and obtains the shaft torque of the rotating shaft or an index that correlates with the shaft torque.
- the third index T' is used, the pressing load on the sliding surface or the index that correlates with the pressing load is used as the fourth index F', and the third index T'and the fourth index F'are acquired, and the vertical axis is Plot the acquired third index T'and fourth index F'on the chart representing the third index T'and the horizontal axis representing the fourth index F'is repeated at least twice, and the line (T-) appearing in the chart.
- the lubrication state of the sliding surface is estimated based on the inclination of the tangent line of the T'-F'line and the section of the tangent line, and the lubrication state is estimated before seizure occurs. You can catch the signs. Then, by performing a process for preventing seizure or the like at the timing when a sign of seizure or the like is caught, seizure or the like can be prevented in advance.
- the lubrication state estimation device 53 and the method it is sufficient to know the positive / negative of the slope of the tangent of the TF line and the positive / negative of the intercept of the tangent of the TF line. No value is required. Therefore, according to the lubrication state estimation device 53 and the method, it is possible to estimate the lubrication state of the sliding surface between the rotating shaft and the bearing in an actual machine in which it is difficult to measure an exact value. In addition, the soundness of fluid lubrication can be evaluated when it is estimated to be fluid lubrication, and the ratio of boundary lubrication to mixed lubrication can be estimated when it is estimated to be mixed lubrication.
- the lubrication state estimation systems 50 and 50A according to the first and second embodiments can be applied to, for example, a slide bearing device 60.
- the slide bearing device 60 exemplified in FIG. 16 is a lubrication state estimation system that estimates the lubrication state of the bearing member 62 that supports the rotary shaft 61 via the lubricating film 63 and the sliding surfaces of the rotary shaft 61 and the bearing member 62. 50 (and / or lubrication state estimation system 50A) is provided.
- the slide bearing device 60 exemplified in FIG. 16 is a journal slide shaft, it may be a thrust slide bearing.
- the lubrication state estimation systems 50 and 50A according to the first and second embodiments can be applied to, for example, a mechanical device 65 including a set of sliding members 66 and 67.
- the mechanical device 65 exemplified in FIG. 17 has a set of sliding members 66, 67 that move relative to each other while being in contact with each other via a lubricating film 68, and a lubrication state of the sliding surfaces of the set of sliding members 66, 67.
- the lubrication state estimation system 50 (and / or the lubrication state estimation system 50A) for estimating the above is provided.
- the lubrication state estimation systems 50 and 50A are not limited to the slide bearing device 60, and the lubrication state of the sliding surfaces of two objects that perform curved motion, linear motion, or reciprocating motion. Can be widely used to estimate.
- FIG. 18 is a diagram showing a schematic configuration of the rotary crusher 100 used in the actual machine simulated test.
- the rotary crusher 100 shown in FIG. 18 is a gyre crusher or cone crusher provided with a spindle 5 rotatably provided in a crushing chamber 16 formed inside the frames 31 and 32, and estimates the lubrication state.
- the configuration of the crusher 100 itself excluding the system 50 is known.
- the rotary crusher 100 is arranged in a central portion of an internal space formed by an upper frame 31 and a lower frame 32 connected to the upper frame 31, with a central axis inclined with respect to the central axis of the crusher 100.
- the main shaft 5 is provided.
- the lower part of the spindle 5 is rotatably inserted into the eccentric sleeve 4.
- the eccentric sleeve 4 is rotatably fitted into the boss 7 formed on the lower frame 32.
- the lower portion of the eccentric sleeve 4 is supported by a thrust slide bearing 23 provided in the lower frame 32.
- the lower end of the spindle 5 is supported by the spindle thrust bearing 2 provided in the piston of the hydraulic cylinder 6 for raising and lowering the spindle.
- the upper end of the spindle 5 is rotatably supported by an upper bearing 17 provided on a spider 18 attached to the upper end of the upper frame 31.
- a hydraulic chamber 27 is formed above the eccentric sleeve 4 and the boss 7 on the inner peripheral side of the cylindrical partition plate 24.
- Lubricant is supplied between the outer peripheral surface of the main shaft 5 and the inner peripheral surface of the eccentric sleeve 4, and between the outer peripheral surface of the eccentric sleeve 4 and the inner peripheral surface of the boss 7.
- the journal plain bearing formed between the outer peripheral surface of the spindle 5 and the inner peripheral surface of the eccentric sleeve 4 is referred to as a "spindle bearing 10", and is between the outer peripheral surface of the eccentric sleeve 4 and the inner peripheral surface of the boss 7.
- the journal sliding bearing formed in the above is referred to as a "sleeve bearing 11".
- the multiple bearing formed by the spindle bearing 10 and the sleeve bearing 11 is referred to as a "lower bearing 15".
- the upper part of the main shaft 5 constitutes a mantle 12 whose outer peripheral surface forms a conical surface.
- a mantle 13 whose outer surface forms a conical surface is attached to the outside of the mantle 12.
- a concave 14 is provided on the inner surface of the upper frame 31. The inner surface of the concave 14 and the outer surface of the mantle 13 form a crushing chamber 16 having a wedge-shaped vertical cross section.
- Power is transmitted from the drive shaft 8a driven by the drive motor 8 provided outside the machine to the eccentric sleeve 4 via the power transmission mechanism 20 including the pulley 22, the horizontal shaft, and the bevel gear 19.
- the eccentric sleeve 4 rotates, the spindle 5 performs an eccentric turning motion, that is, a so-called precession motion, with respect to the upper frame 31.
- the distance between the outer surface of the mantle 13 and the inner surface of the concave 14 changes according to the turning position of the spindle 5.
- the crushed material that has fallen into the crushing chamber 16 is crushed between the concave 14 and the mantle 13, and is collected as a crushed product from below the lower frame 32.
- the rotary crusher 100 having the above configuration includes a cylinder pressure measuring device 55 that measures the cylinder pressure of the hydraulic cylinder 6 for raising and lowering the spindle, and a shaft power measuring device that measures the shaft power (output) of the drive shaft 8a of the drive motor 8.
- a lubrication state estimation system 50 (and / or a lubrication state estimation system 50A) including a lubrication state estimation device 53 and a lubrication state estimation device 53 is provided.
- the cylinder pressure measuring device 55 may be a hydraulic sensor provided in the hydraulic cylinder 6 for raising and lowering the spindle.
- the shaft power measuring instrument 56 may be a power meter or a torque sensor provided in the drive motor 8.
- the cylinder pressure measuring device 55 and the shaft power measuring device 56 correspond to the index measuring device 51.
- ⁇ shaft power / cylinder pressure ⁇ is used as the first index that correlates with the friction coefficient f of the sliding surface in the lower bearing 15
- ⁇ cylinder pressure ⁇ is used as the second index that correlates with the physical quantity S * in the lower bearing 15. board.
- the loss of the lower bearing 15 is expressed by ⁇ friction coefficient f x cylinder pressure x coefficient ⁇ .
- friction coefficient f x cylinder pressure x coefficient ⁇ Approximately the energy balance during load operation of the rotary crusher 100, the shaft power of the drive shaft 8a, the crushing work, the loss of the lower bearing 15, the transmission loss of the power transmission mechanism 20, the mechanical loss of the drive motor 8, And, the sum of the losses of the bearings excluding the lower bearing 15 is balanced.
- the rotation speed of the spindle 5 is kept substantially constant. Under conditions where the load is sufficiently large and steep load fluctuations can be ignored, the coefficient of friction f of the lower bearing 15 correlates with ⁇ shaft power / cylinder pressure ⁇ .
- ⁇ shaft power / cylinder pressure ⁇ can be used as the first index that correlates with the friction coefficient f of the lower bearing 15.
- an index that correlates with the shaft power may be used instead of the shaft power, or an index that correlates with the cylinder pressure may be used instead of the cylinder pressure.
- the positive / negative of the time change rate of the physical quantity S * of the lower bearing 15 corresponds to the positive / negative of the time change rate of the bearing load of the lower bearing 15 (that is, the pressing load F of the sliding surface).
- the bearing load of the lower bearing 15 is expressed by ⁇ cylinder pressure ⁇ coefficient ⁇ . From the above, ⁇ cylinder pressure ⁇ can be used as the second index that correlates with the physical quantity S *.
- an index that correlates with the cylinder pressure may be used instead of the cylinder pressure.
- the vertical axis of this chart represents the first index or the second index, and the horizontal axis represents the elapsed time.
- the correlation between the first index and the second index shows a negative correlation under fluid lubrication, but eventually changes to a positive correlation at a certain timing.
- the lubrication state estimation system 50 included in the rotary crusher 100 the lubrication state changes at the timing when the correlation between the first index and the second index changes from a negative correlation to a positive correlation. It is possible to detect the transition from fluid lubrication to mixed lubrication.
- the concave 14 and the main shaft 5 arranged inside the concave 14, the mantle 13 provided on the main shaft 5, and the lower part of the main shaft 5 are included.
- the eccentric sleeve 4 rotatably inserted, the boss 7 into which the eccentric sleeve 4 is rotatably inserted, the drive shaft 8a for rotationally driving the eccentric sleeve 4 via the power transmission mechanism 20, and the drive shaft 8a for rotational drive.
- the drive motor 8 is provided, a hydraulic cylinder 6 for supporting the spindle 5 so as to be able to move up and down, at least one slide bearing device, and lubrication state estimation systems 50 and 50A for estimating the lubrication state of the sliding surface in the slide bearing device. ..
- lubrication state estimation system 50, 50A at least one of the lubrication state estimation systems 50, 50A according to the first embodiment and the second embodiment may be applied to the rotary crusher 100.
- the lubrication state estimation systems 50 and 50A are formed between the journal sliding bearing (spindle bearing 10) formed between the spindle 5 and the eccentric sleeve 4, and between the eccentric sleeve 4 and the boss 7.
- the double bearing (lower bearing 15) made of the journal sliding bearing (sleeve bearing 11) the lubrication state of the sliding surface is estimated.
- the lubrication state estimation systems 50 and 50A estimate the lubrication state of the sliding surface of the lower bearing 15, but the lubrication state estimation systems 50 and 50A are other sliding surfaces included in the rotary crusher 100. It may be configured to estimate the lubrication state of. That is, the lubrication state estimation systems 50 and 50A include the spindle bearing 10, the sleeve bearing 11, the spindle thrust bearing 2 formed between the spindle 5 and the hydraulic cylinder 6, the thrust slip bearing 23 of the eccentric sleeve 4, and the spindle 5. At least one of the journal sliding bearings (upper bearing 17) supporting the upper part of the bearing may be configured to estimate the lubrication state of the sliding surface.
- the lubrication state estimation systems 50 and 50A use the cylinder pressure measuring device 55 for measuring the cylinder pressure of the hydraulic cylinder 6 and the drive motor 8 as the index measuring device 51.
- the shaft power measuring device 56 for measuring the shaft power is included.
- the cylinder pressure measuring device 55 is included in the index measuring device of the first index (correlated with f), the second index ( correlated with S * ), and the fourth index (correlated with F).
- the shaft power measuring instrument 56 is included in the index measuring instrument of the first index (correlated with f) and the third index (correlated with T).
- the lubrication state estimation system 50 correlates with ⁇ an index that correlates with the shaft power or the shaft power / an index that correlates with the cylinder pressure or the cylinder pressure ⁇ , assuming that the rotation speed of the eccentric sleeve 4 and the viscosity of the lubricating oil are constant.
- the function that correlates with ⁇ the index that correlates with the cylinder pressure or the cylinder pressure ⁇ is used as the second index, and these indexes are used for estimating the lubrication state of the sliding surface.
- the lubrication state estimation system 50A assumes that the rotational speed of the eccentric sleeve 4 and the viscosity of the lubricating oil are constant, and uses a function that correlates with ⁇ an index that correlates with axial power or axial power ⁇ as a third index, and ⁇ cylinder. An index that correlates with pressure or cylinder pressure ⁇ is used as the fourth index, and these indexes are used to estimate the lubrication state of the sliding surface.
- the first index, the second index, and the third index are used by using the process data which is relatively easy to measure during the operation of the rotary crusher 100. Since the index and the fourth index are obtained, the lubrication state estimation systems 50 and 50A can be easily applied to the rotary crusher 100. Further, since the lubrication state estimation systems 50 and 50A can constantly and continuously estimate the lubrication state of bearings such as the lower bearing 15, it is possible to estimate the secular change of the bearing in addition to the lubrication state of the bearing. can.
- the shaft power and the cylinder pressure of the rotary crusher 100 are measured, and the measured values of the shaft power and the cylinder pressure are estimated.
- the lubrication state of the sliding bearing (lower bearing 15 in this embodiment).
- other physical quantities that can be used as the first to fourth indicators may be used.
- the first index may be a measured value including work, bearing loss, and other losses as long as it is a physical quantity that correlates with the friction coefficient f of the slide bearing to be estimated.
- the second index may be a measured value including work, bearing loss, and other losses as long as it is an index that correlates with the physical quantity S * to be estimated.
- the third index may be a measured value including work, bearing loss, and other losses as long as it is an index that correlates with the shaft torque.
- the fourth index may be a measured value including work, bearing loss, and other losses as long as it is an index that correlates with the load on the bearing sliding surface (pressing load F).
- the shaft power of the drive motor 8 the shaft power obtained from the shaft torque and the rotation speed of the spindle 5, the motor power obtained from the current and the voltage applied to the drive motor 8, and the like may be used.
- the shaft torque may be substituted by the strain of the spindle 5 or the stress of the spindle 5.
- the output torque of the drive motor 8 shaft torque of the drive shaft 8a
- the displacement amount of the cylinder may be used instead of the cylinder pressure.
- one spindle 5 is supported by both a lower bearing 15 which is a journal sliding bearing and a spindle thrust bearing 2 which is a thrust sliding bearing.
- the lower bearing 15 is a so-called “fluid lubrication bearing” in which the normal lubrication state is fluid lubrication. In a fluid-lubricated bearing, the lubrication state changes from fluid lubrication to boundary lubrication via mixed lubrication.
- the spindle thrust bearing 2 is a so-called "boundary lubrication bearing” in which the normal lubrication state is boundary lubrication.
- the viscosity ⁇ and the sliding speed v are constant.
- ⁇ the shaft power of the drive shaft 8a (or the index that correlates with the shaft power) / the cylinder pressure of the hydraulic cylinder 6 (or the index that correlates with the cylinder pressure) ⁇ is used as the fifth index.
- ⁇ 1 / cylinder pressure of the hydraulic cylinder 6 (or an index correlating with the cylinder pressure) ⁇ is used as the sixth index.
- FIG. 20A is a 5th index-6th index diagram of the lower bearing 15.
- the fifth index-6th index diagram is a log-log graph in which the vertical axis represents the fifth index and the horizontal axis represents the sixth index.
- the slope of the tangent of the fifth index-6th index line (that is, the rate of change of the fifth index with respect to the sixth index) is positive.
- the inclination of the tangent line of the fifth index-6th index line is negative.
- FIG. 20B is a 5th index-6th index diagram of the spindle thrust bearing 2.
- the scales on the horizontal axis of FIGS. 20A and 20B correspond to each other.
- the lubrication state of the spindle thrust bearing 2 is boundary lubrication
- the inclination of the tangent line of the fifth index-6th index line is almost 0.
- the slope of the tangent line of the fifth index to the sixth index line is negative.
- the lubrication state of the spindle thrust bearing 2 is higher than the inclination of the tangent of the fifth index-6th index line when the lubrication state of the lower bearing 15 is mixed lubrication.
- the slope of the tangent of the 5th index-6th index line when the scuffing phenomenon is occurring is steeper.
- the rate of change R1 of the fifth index with respect to the sixth index when the lubrication state of the lower bearing 15 is mixed lubrication is the fifth index with respect to the sixth index when the lubrication state of the spindle thrust bearing 2 is mixed lubrication. Larger than the rate of change R2.
- Both R1 and R2 are negative values.
- the lubrication state estimation system 50B has at least one fifth index measuring instrument 51e for measuring the fifth index and at least one for measuring the sixth index.
- the lower bearing 15 (fluid lubrication bearing) and the spindle thrust bearing 2 are obtained based on the 6th index measuring instrument 51f and the measured values of the 5th index and the 6th index, and the rate of change R of the 5th index with respect to the 6th index.
- a lubrication state estimation device 53 for estimating the lubrication state of the (boundary lubrication bearing) is provided.
- the fifth index measuring instrument 51e may include the shaft power measuring instrument 56 and the cylinder pressure measuring instrument 55 described in the third embodiment of the first and second embodiments.
- the sixth index measuring device 51f may include the cylinder pressure measuring device 55 described in the third embodiment of the first and second embodiments.
- FIG. 22 is a flowchart illustrating a processing flow of the lubrication state estimation device 53.
- the lubrication state estimation device 53 acquires the measured value of the fifth index from the fifth index measuring device 51e, and acquires the measured value of the sixth index from the sixth index measuring device 51f (step S51). ).
- the lubrication state estimation device 53 obtains the rate of change R of the fifth index with respect to the sixth index (step S52). If the rate of change R is a positive value (YES in step S53), the lubrication state estimation device 53 considers that the lubrication state of the lower bearing 15 and the spindle thrust bearing 2 is normal, and returns the process to step S51.
- the lubrication state estimation device 53 compares the rate of change R with the predetermined first threshold value ⁇ 1 (step S54).
- the first threshold value ⁇ 1 is a value smaller than 0.
- the lubrication state estimation device 53 estimates that a scuffing phenomenon has occurred in the spindle thrust bearing 2 (boundary lubrication bearing) when the rate of change R is equal to or less than the first threshold value ⁇ 1 (YES in step S54).
- An alarm for notifying the abnormality of the spindle thrust bearing 2 is output from the illustrated alarm device (step S55).
- the lubrication state estimation device 53 compares the rate of change R with the predetermined second threshold value ⁇ 2 (step S56).
- the second threshold value ⁇ 2 is a value larger than the first threshold value ⁇ 1 and smaller than 0 (0> ⁇ 2> ⁇ 1).
- the lubrication state estimation device 53 occupies the mixed lubrication in the lower bearing 15 (fluid lubrication bearing).
- the ratio of boundary lubrication is equal to or higher than a predetermined ratio, and an alarm for notifying an abnormality of the lower bearing 15 is output from an alarm device (not shown) (step S57).
- the "predetermined ratio” is a value such that seizure of the sliding surface does not occur, but seizure of the sliding surface may occur in the near future if sliding is continued.
- step S56 If the rate of change R is larger than the second threshold value ⁇ 2 in step S56 (NO in step S56), the lubrication state estimation device 53 outputs a warning regarding the lubrication state of the lower bearing 15 from an alarm device (not shown) (step). S58), the process is returned to step S51. This warning only warns that the thickness of the lubricating film has decreased, but the operator can receive the warning and take appropriate measures.
- the concave, the main shaft 5 arranged inside the concave 14, the mantle 13 provided on the main shaft 5, and the lower part of the main shaft 5 are included.
- a lower bearing 15 composed of a sleeve bearing 11 which is a second fluid lubricated bearing, a spindle thrust bearing 2 which is a boundary lubricated bearing formed between the spindle 5 and the hydraulic cylinder 6, and at least 1 for measuring the fifth index.
- One fifth index measuring instrument 51e at least one sixth index measuring instrument 51f for measuring the sixth index, and a first fluid lubrication bearing and a second fluid lubrication based on the rate of change R of the fifth index with respect to the sixth index.
- the bearing and the boundary lubrication bearing are provided with a lubrication state estimation device 53 for estimating the lubrication state of the bearing.
- the fifth index and the sixth index are measured, and the first fluid is based on the rate of change of the fifth index with respect to the sixth index. It includes estimating the lubrication state of the lubrication bearing, the second fluid lubrication bearing and the boundary lubrication bearing.
- the lubrication state estimation device 53 estimates that a scuffing phenomenon occurs in the spindle thrust bearing 2 (boundary lubrication bearing) when the rate of change R is smaller than 0 and equal to or less than a predetermined first threshold value ⁇ 1. do.
- the lubrication state estimation method when the step of estimating the lubrication state is equal to or less than a predetermined first threshold value ⁇ 1 in which the rate of change R is smaller than 0, the scuffing phenomenon occurs in the spindle thrust bearing 2 (boundary lubrication bearing). Includes estimating what is happening.
- the lubrication state estimation device 53 has a lower bearing 15 (first fluid lubrication bearing) when the rate of change R is greater than or equal to the first threshold value ⁇ 1 and smaller than 0 by a predetermined second threshold value ⁇ 2 or less. It is estimated that the ratio of boundary lubrication to the mixed lubrication in (at least one of the second fluid lubrication bearings) is equal to or higher than the predetermined ratio.
- the lubrication state estimation method when the lubrication state is estimated when the rate of change R is larger than the predetermined first threshold value ⁇ 1 smaller than 0 and smaller than the predetermined second threshold value ⁇ 2 smaller than 0. , Including estimating that the ratio of boundary lubrication to the mixed lubrication in the lower bearing 15 (at least one of the first fluid lubrication bearing and the second fluid lubrication bearing) is equal to or more than a predetermined ratio.
- the lubrication state of the lower bearing 15 which is a fluid lubrication bearing and the spindle thrust bearing 2 which is a boundary lubrication bearing is individually estimated by one system. However, from this, it is possible to estimate where the sign of seizure is occurring.
- the lubrication state estimation method according to the present embodiment the lubrication state of the fluid lubrication bearing and the boundary lubrication bearing is individually estimated in a series of processes, and by this, a seizure sign is generated. Can be estimated. That is, it is not necessary to individually estimate the lubrication state of the fluid-lubricated bearing and the boundary-lubricated bearing.
- the number of devices included in the rotary crusher 100 for estimating the lubrication state of both the fluid-lubricated bearing and the boundary-lubricated bearing can be reduced.
- the parts to be replaced can be specified without stopping the operation of the rotary crusher 100 and disassembling it.
- the functions of the lubrication state estimation device 53 disclosed herein include general-purpose processors, dedicated processors, integrated circuits, ASICs (Application Specific Integrated Circuits), conventional circuits, which are configured or programmed to perform the disclosed functions. And / or can be performed using a circuit containing a combination thereof or a processing circuit.
- a processor is considered a processing circuit or circuit because it includes transistors and other circuits.
- a circuit, unit, or means is hardware that performs the listed functions.
- the hardware may be the hardware disclosed herein, or it may be other known hardware that is programmed or configured to perform the listed functions. If the hardware is a processor considered to be a type of circuit, the circuit, means, or unit is a combination of hardware and software, and the software is used to configure the hardware and / or processor.
- the lubrication state estimation device 53 which is a component of the lubrication state estimation systems 50, 50A, 50B, and various index measuring instruments do not have to be provided at the same place.
- various index measuring instruments may be provided incidentally to the rotary crusher 100, and at least a part of the functions of the lubrication state estimation device 53 may be provided at a remote location from the rotary crusher 100.
- the value of the index detected by various index detectors is transmitted to the lubrication state estimation device 53 through the communication network, and the lubrication state estimation device 53 transmits the calculated lubrication state estimation result to the rotary crusher through the communication network. It may be a control device of 100 or the like.
- the function of the lubrication state estimation device 53 may be provided by the cloud service.
- the cloud server accessed from the computer may function as the lubrication state estimation device 53 by executing a predetermined program, and may return the failure sign diagnosis result to the computer.
- the lubrication state estimation device 53 may store the estimation result of the lubrication state in the cloud storage.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Food Science & Technology (AREA)
- Sliding-Contact Bearings (AREA)
- Crushing And Grinding (AREA)
- Disintegrating Or Milling (AREA)
Abstract
相対運動をする2つの物体の摺動面の潤滑状態を推定する潤滑状態推定方法は、第1指標及び第2指標を取得すること、及び、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関に基づいて、摺動面の潤滑状態が流体潤滑から混合潤滑へ変化したことを検出することを含む。第1指標は摺動面の摩擦係数又は当該摩擦係数と相関する指標であり、第2指標はS*=ηv/F(但し、ηは摺動面に介在する潤滑剤の粘度、vは摺動面の摺動速度、Fは摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標である。
Description
本開示は、相対運動をする2つの物体の摺動面の潤滑状態を推定する技術に関する。
従来、滑り軸受の多くは、軸の回転によって軸と軸受部材との摺動面の間に潤滑剤が引き込まれ、その潤滑剤により形成された潤滑膜の圧力によって軸を支えるように設計される。そのため、軸と軸受部材との摺動面の潤滑状態が適切でなければ、摺動面の異常な摩耗や焼付きが短時間で発生する。そこで、特許文献1~2では、軸受装置における異常な摩耗や焼付きを防ぐ技術が提案されている。
特許文献1には、潤滑膜が形成された軸受メタルと、当該軸受メタルを保持する軸受支持部とから成る滑り軸受において、温度センサで軸受メタルの周りの温度を検出し、温度上昇に基づいて潤滑不良を知ることが開示されている。
特許文献2には、滑り軸受等におけるラビング(回転部と静止部との接触)の有無を判定する手法として、過電流型センサによる軸振動、圧電型加速度センサによる軸受箱振動、及び、回転軸と軸受とが接触するときに発生する音響信号などを利用することが開示されている。また、特許文献2には、滑り軸受の稼働時に発生する振動の加速度を表す波形データと滑り軸受の軸回転周期とを検出し、加速度波形データをフーリエ変換することによって周波数領域の加速度スペクトルを求め、加速度スペクトルをケプストラム分析して得た波形データに基づいて滑り軸受の異常の発生の有無を判断することが開示されている。
ところで、相対運動をする2面間における潤滑状態を説明するために、ストライベック曲線が利用される。図1に例示されるストライベック曲線は、相対運動をする2つの物体の摺動面において、摩擦係数fと、潤滑膜の粘度μ、摺動面の摺動速度v及び摺動面の押付荷重Fの3要素を組み合わせた物理量S*(S*=μv/F)との関係を示す。また、ストライベック曲線には、潤滑状態が流体潤滑から混合潤滑を経て境界潤滑へ遷移するのに伴って摩擦係数の特性が変化する様子が示されている。
流体潤滑では、摺動面同士の間に表面粗さに比べて十分に厚い潤滑膜が介在し、摺動面同士が連続する潤滑膜によって完全に離れている。混合潤滑では、潤滑膜が流体潤滑よりも薄くなって、摺動面の凸部同士の接触が局所的に生じている。境界潤滑では、潤滑膜が混合潤滑よりも薄くなり、摺動面の凸部同士に分子レベルの潤滑膜を介した接触が生じている。
上記の特許文献1,2では、軸又は軸受の振動数の変化や、軸受の温度変化に基づいて、軸受の潤滑状態の異常を検出する。しかし、振動数や温度が潤滑状態の異常を検出できる程度に変化した時点で既に摺動面には異常な摩耗や焼付き(以下、「焼付き等」と称する)が生じており、それらを未然に防ぐことは難しい。
また、摺動面の摺動条件と潤滑状態との定性的な関係は、ストライベック線図を用いて説明できることは知られている。しかし、実機や試験機において図1に例示される理想的なストライベック曲線を得ることは難しく、再現性が低い。この理由に、摺動面の摩耗や変形、熱膨張、発熱などの影響の他、摺動面の摩擦係数や潤滑膜の粘度の計測が難しいことなどが挙げられる。従って、実機において各種測定値をストライベック線図に整理(プロット)しても、それを用いて摺動面の潤滑状態の変化を推定することは難しい。
本開示は以上の事情に鑑みてされたものであり、その目的は、相対運動をする2つの物体の摺動面の潤滑状態を推定し、これにより摺動面の焼付き等を未然に防ぐことにある。
摺動面の焼付き等を未然に防ぐためには、潤滑状態が流体潤滑から混合潤滑に遷移した後、境界潤滑に遷移して焼付きが発生する前に、焼付き等の予兆を検知し、焼付き等を未然に防止するための処理を行うことが望ましい。具体的な一例として、潤滑状態が流体潤滑から混合潤滑に遷移した状態を焼付きの予兆と見做して、境界潤滑に遷移する前に流体潤滑から混合潤滑への遷移を検知できれば、焼付き等を未然に防ぐことが可能になる。そこで、本願の発明者らは、潤滑状態が流体潤滑から混合潤滑へ遷移した後、境界潤滑に遷移する前に摺動面の摩擦係数fの時間変化率の正負と物理量S*の時間変化率の正負との相関関係が変化するという現象を利用して、流体潤滑されている摺動面の潤滑状態が混合潤滑に遷移したことを推定することに想到した。
本開示の一態様に係る潤滑状態推定装置は、相対運動をする2つの物体の摺動面の潤滑状態を推定する潤滑状態推定装置であって、
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、
S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記プロセッサが、前記第1指標及び前記第2指標を取得し、前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定するものである。
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、
S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記プロセッサが、前記第1指標及び前記第2指標を取得し、前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定するものである。
本開示の一態様に係る潤滑状態推定方法は、相対運動をする2つの物体の摺動面の潤滑状態を推定する潤滑状態推定方法であって、
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記第1指標及び前記第2指標を取得すること、及び、
前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定することを含むものである。
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記第1指標及び前記第2指標を取得すること、及び、
前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定することを含むものである。
前述の通り、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関が、摺動面の潤滑状態が流体潤滑ときと混合潤滑のときとで異なる。このことを利用して、上記潤滑状態推定装置及び方法では、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関の変化に基づいて、流体潤滑されている摺動面の潤滑状態を推定することができる。そして、この推定結果を利用して、潤滑状態が境界潤滑に遷移して焼付き等が生じる前にその予兆を捉えることができる。そして、焼付き等の予兆を捉えたタイミングで焼付き等を防止するための処理を行うことによって、焼付き等を未然に防ぐことができる。
更に、上記潤滑状態推定装置及び方法では、第1指標及び第2指標について時間変化率の正負がわかれば足りるので、第1指標及び第2指標の厳密な値は要求されない。よって、上記潤滑状態推定装置及び方法によれば、厳密な値を測定することの困難な実機において、相対運動をする2つの物体の摺動面の潤滑状態を推定することができる。
また、本開示の別の一態様に係る潤滑状態推定装置は、回転軸と軸受との摺動面の潤滑状態を推定する潤滑状態推定装置であって、
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標とし、前記摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標とし、
前記プロセッサが、前記第3指標及び前記第4指標を取得し、縦軸が前記第3指標を表し横軸が前記第4指標を表す図表に取得した前記第3指標及び前記第4指標をプロットすることを少なくとも2回以上繰り返し、前記図表に表れる線の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて、前記摺動面の潤滑状態を推定するものである。
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標とし、前記摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標とし、
前記プロセッサが、前記第3指標及び前記第4指標を取得し、縦軸が前記第3指標を表し横軸が前記第4指標を表す図表に取得した前記第3指標及び前記第4指標をプロットすることを少なくとも2回以上繰り返し、前記図表に表れる線の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて、前記摺動面の潤滑状態を推定するものである。
同様に、本開示の別の一態様に係る潤滑状態推定方法は、回転軸と軸受との摺動面の潤滑状態を推定する潤滑状態推定方法であって、前記回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標とし、前記摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標とし、前記第3指標及び前記第4指標を取得すること、及び、縦軸が前記第3指標を表し横軸が前記第4指標を表す図表に取得した前記第3指標及び前記第4指標をプロットすることを少なくとも2回以上繰り返し、前記図表に表れる線(T-F線)の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて前記摺動面の潤滑状態を推定することを含むものである。
流体潤滑下において、T-F線の接線の傾きは押付荷重Fの増加に伴って略一定又は減少し、T-F線の接線の切片は0又は正の値であることが分かっている。また、混合潤滑下において、T-F線の接線の傾きは押付荷重Fの増加(即ち、混合潤滑における境界潤滑の割合の増加)に従って大きくなり、T-F線の接線の切片は0又負の値であることが分かっている。このことから、上記潤滑状態推定装置及び方法によれば、上記T-F線の接線の傾き及び接線の切片に基づいて、摺動面の潤滑状態を推定して、焼付き等が生じる前にその予兆を捉えることができる。そして、焼付き等の予兆を捉えたタイミングで焼付き等を防止するための処理を行うことによって、焼付き等を未然に防ぐことができる。
更に、上記潤滑状態推定装置及び方法では、T-F線の接線の傾きの正負と、T-F線の接線の切片の正負とがわかれば足りるので、第3指標及び第4指標の厳密な値は要求されない。よって、上記潤滑状態推定装置及び方法によれば、厳密な値を測定することの困難な実機において、回転軸と軸受との摺動面の潤滑状態を推定することができる。
また、本開示の更に別の一態様に係る旋動式破砕機は、
コンケーブと、
前記コンケーブの内部に配置された主軸と、
前記主軸に設けられたマントルと、
前記主軸の下部が回転自在に挿入された偏心スリーブと、
前記偏心スリーブが回転自在に挿入されたボスと、
前記偏心スリーブを回転駆動する駆動軸と、
前記駆動軸を回転駆動する駆動モータと、
前記主軸を昇降可能に支持する油圧シリンダと、
前記主軸と前記偏心スリーブとの間に形成された第1流体潤滑軸受と、
前記偏心スリーブと前記ボスとの間に形成された第2流体潤滑軸受と、
前記主軸と前記油圧シリンダとの間に形成された境界潤滑軸受と、
{前記駆動軸の軸動力又は当該軸動力と相関する指標/前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第5指標とし、前記第5指標を測定する少なくとも1つの第5指標測定器と、
{1/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第6指標とし、前記第6指標を測定する少なくとも1つの第6指標測定器と、
前記第6指標に対する前記第5指標の変化率に基づいて前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定する潤滑状態推定装置とを備えるものである。
同様に、本開示の更に別の一態様に係る潤滑状態推定方法は、コンケーブと、前記コンケーブの内部に配置された主軸と、前記主軸に設けられたマントルと、前記主軸の下部が回転自在に挿入された偏心スリーブと、前記偏心スリーブが回転自在に挿入されたボスと、前記偏心スリーブを回転駆動する駆動軸と、前記駆動軸を回転駆動する駆動モータと、前記主軸を昇降可能に支持する油圧シリンダと、前記主軸と前記偏心スリーブとの間に形成された第1流体潤滑軸受と、前記偏心スリーブと前記ボスとの間に形成された第2流体潤滑軸受と、前記主軸と前記油圧シリンダとの間に形成された境界潤滑軸受とを備える旋動式破砕機において、前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定する潤滑状態推定方法であって、
{前記駆動軸の軸動力又は当該軸動力と相関する指標/前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第5指標とし、
{1/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第6指標とし、
前記第5指標及び前記第6指標を取得すること、及び
前記第6指標に対する前記第5指標の変化率に基づいて前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定することを含むものである。
{前記駆動軸の軸動力又は当該軸動力と相関する指標/前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第5指標とし、
{1/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第6指標とし、
前記第5指標及び前記第6指標を取得すること、及び
前記第6指標に対する前記第5指標の変化率に基づいて前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定することを含むものである。
上記旋動式破砕機によれば、流体潤滑軸受と境界潤滑軸受との潤滑状態を1つの装置で個別に推定し、これにより、どこに焼付き予兆が発生しているのかを推定することができる。同様に、上記潤滑状態推定方法によれば、一連の処理で、流体潤滑軸受と境界潤滑軸受との潤滑状態を個別に推定し、これにより、どこに焼付き予兆が発生しているのかを推定することができる。つまり、流体潤滑軸受と境界潤滑軸受とについて、夫々に潤滑状態を推定する計測を個別に行う必要がない。これにより、流体潤滑軸受と境界潤滑軸受の双方の軸受の潤滑状態の推定のために旋動式破砕機が備える機器の点数を削減することができる。そのうえ、焼付き予兆が発生している箇所を推定できるので、旋動式破砕機の運転を止めて分解しなくても、交換すべき部品を特定することができる。
本開示によれば、相対運動をする2つの物体の摺動面の潤滑状態の変化を推定し、これにより摺動面の異常な摩耗や焼付きを未然に防ぐことができる。
〔第1実施形態〕
本開示の第1実施形態を説明する。
本開示の第1実施形態を説明する。
図1において、ストライベック曲線は、物理量S*の減少に伴って摩擦係数fが減少する第1セクション(I)と、物理量S*の減少に伴って摩擦係数fが増加する第2セクション(II)と、物理量S*が減少しても摩擦係数fが比較的大きな値に保持される第3セクション(III)とを含む。第1セクション(I)と第2セクション(II)との間に、ストライベック曲線の傾きの正負が変化する点が存在する。
摺動面の摺動条件は時間の経過に伴って変化する。例えば、時間の経過に伴い、摺動面に懸かる荷重Fが増加、又は、摺動面の摺動速度vが減少、又は、潤滑剤の粘度μが減少するとする。このとき物理量S*は、摺動条件が時間に伴い漸次減少する。つまり、摺動条件の変化に伴う物理量S*の時間変化率が負であるならば、摺動面の潤滑状態は、時間の経過に伴ってストライベック曲線上を図表左側へ向かって進行する。第1セクション(I)では、物理量S*の時間変化率は負(減少)であり、摩擦係数fの時間変化率は負(減少)である。このように、摩擦係数fの時間変化率の正負と物理量S*の時間変化率の正負とが整合することを、以下、「正の相関」と称する。一方、第2セクション(II)では、物理量S*の時間変化率は負(減少)であり、摩擦係数fの時間変化率は正(増加)である。このように、摩擦係数fの時間変化率の正負と物理量S*の時間変化率の正負とが逆であることを、以下、「負の相関」と称する。このような摩擦係数fの時間変化率の正負と物理量S*の時間変化率の正負との相関(以下、単に「摩擦係数fと物理量S*の相関」と称する)を表1に示す。
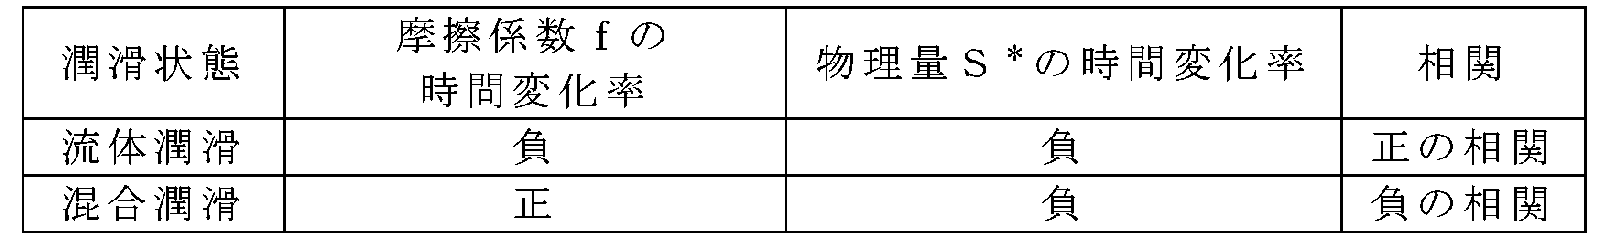
表1において、摩擦係数fは第1指標(摩擦係数f又は当該摩擦係数と相関する指標)に、物理量S*は第2指標(物理量S*又は当該S*と相関する指標)に置き換えても、それら2つの指標間の相関変化から、同様に摺動面の潤滑状態の変化を検知することができる。なお、ここで「相関する指標」の相関は、正の相関、負の相関の何れの指標であっても構わない。このような第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関(以下、単に「第1指標と第2指標の相関」と称する)を表2~5に示す。
表2は、例えば、第1指標は摩擦係数fであり、第2指標は物理量S*である場合があてはまる。表3は、例えば、第1指標が摩擦係数fであり、第2指標が{1/物理量S*}である場合があてはまる。表4は、例えば、第1指標が{1/摩擦係数f}であり、第2指標が物理量S*である場合があてはまる。表5は、例えば、第1指標が{1/摩擦係数f}であり、第2指標が{1/物理量S*}である場合があてはまる。
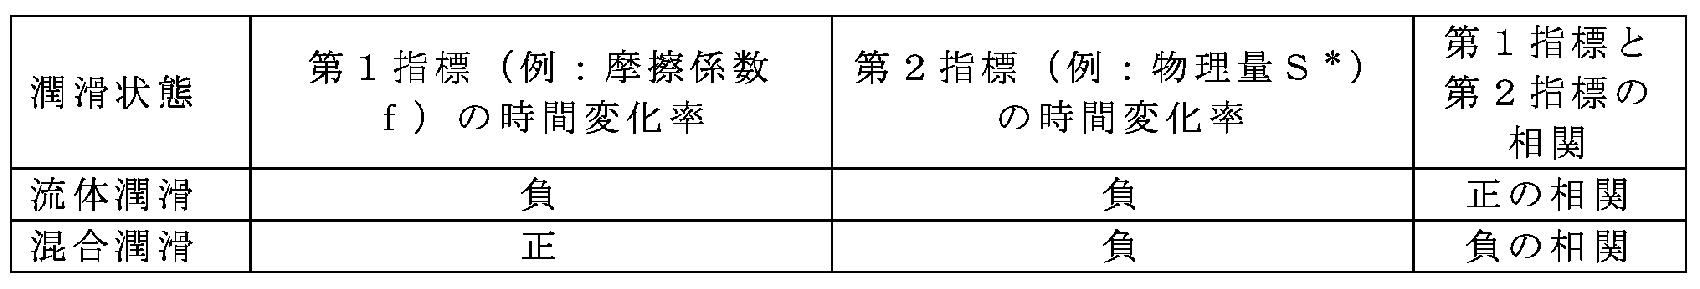
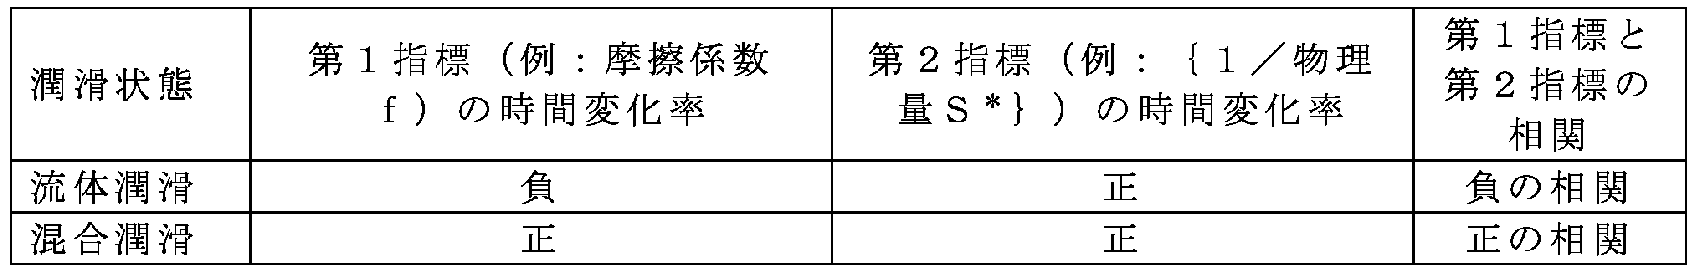
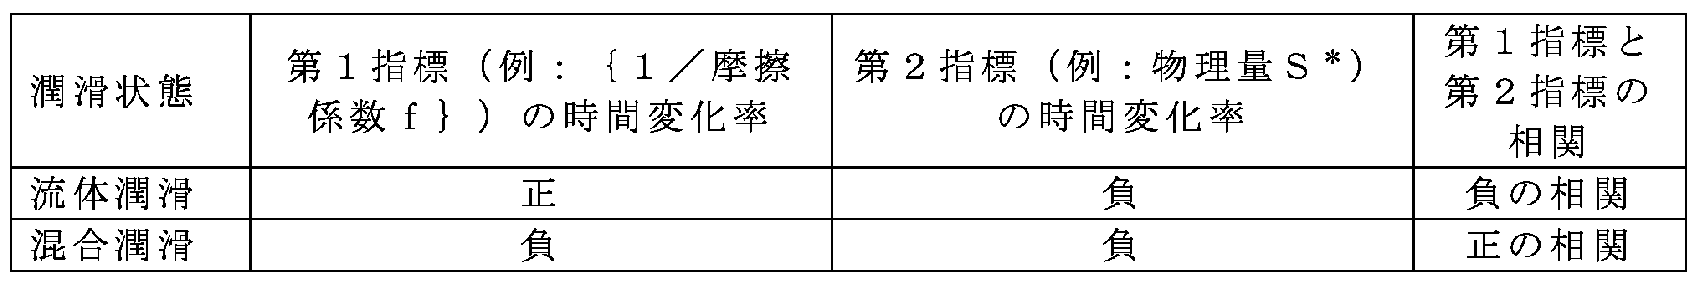
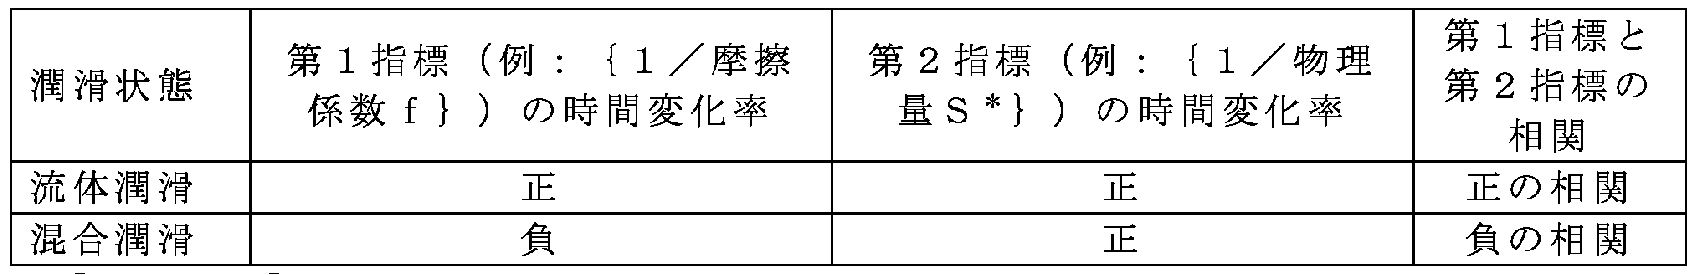
上記のような第1指標と第2指標との相関を検証するために、次に示す検証1,2を行った。検証1では、ジャーナル滑り軸受モデルに関するシミュレーションを行い、検証2では、スラスト滑り軸受に関する要素試験とシミュレーションとを行った。
〔検証1〕
図2は、検証1のシミュレーションで用いたジャーナル滑り軸受モデルを示す図である。このジャーナル滑り軸受モデルは、ジャーナル滑り軸受42に回転軸41が挿入され、ジャーナル滑り軸受42の内周と回転軸41の外周との間に潤滑剤による潤滑膜43が形成されたものである。検証1では、ジャーナル滑り軸受モデルを用いて、回転軸41の回転速度を一定とし、潤滑剤の粘度μを潤滑剤の温度上昇に伴って経時的に低下させる条件下で、回転軸41を回転させて、更に軸受への押付荷重Fを経時的に変動させたときの摩擦係数f及び軸受荷重の経時的変化をシミュレーションで求めた。なお、回転軸41の回転速度は摺動面の摺動速度vと対応する物理量であり、軸受荷重は摺動面の押付荷重Fと対応する物理量である。この検証1の結果を図3に示す。
図2は、検証1のシミュレーションで用いたジャーナル滑り軸受モデルを示す図である。このジャーナル滑り軸受モデルは、ジャーナル滑り軸受42に回転軸41が挿入され、ジャーナル滑り軸受42の内周と回転軸41の外周との間に潤滑剤による潤滑膜43が形成されたものである。検証1では、ジャーナル滑り軸受モデルを用いて、回転軸41の回転速度を一定とし、潤滑剤の粘度μを潤滑剤の温度上昇に伴って経時的に低下させる条件下で、回転軸41を回転させて、更に軸受への押付荷重Fを経時的に変動させたときの摩擦係数f及び軸受荷重の経時的変化をシミュレーションで求めた。なお、回転軸41の回転速度は摺動面の摺動速度vと対応する物理量であり、軸受荷重は摺動面の押付荷重Fと対応する物理量である。この検証1の結果を図3に示す。
図3の図表には、温度上昇により潤滑剤の粘度μを経時的に低下する条件の下で、摺動面の押付荷重F(軸受荷重)の経時的変化と、摩擦係数fの経時的変化とが表されている。ここでは摩擦係数fが第1指標、押付荷重Fが第2指標である。この図表から、流体潤滑下において、押付荷重Fと摩擦係数fとは周期的に変動し、その周期は等しく、且つ、位相差が半周期であることが読み取れる。より詳細には、流体潤滑下において、押付荷重Fが増加する間に摩擦係数fは減少し、押付荷重Fが減少する間に摩擦係数は増加する。即ち、流体潤滑下において、摩擦係数fの時間変化率の正負と押付荷重Fの時間変化率の正負との相関(以下、単に「摩擦係数fと押付荷重Fの相関」と称する)は負の相関を示す。
また、図3の図表から、混合潤滑下において、押付荷重Fと摩擦係数fとは周期的に変動し、その周期は等しく、且つ、同位相であることが読み取れる。より詳細には、混合潤滑下において、押付荷重Fが増加する間に摩擦係数fは増加し、押付荷重Fが減少する間に摩擦係数fは減少する。即ち、混合潤滑下において、摩擦係数fと押付荷重Fの相関は正の相関を示す。
更に、図3の図表から、以下のことがわかる。即ち、流体潤滑下、且つ、流体潤滑が弱くなる(潤滑膜が薄くなる)方向に物理量S*が経時的に変化する場合は、第1指標(摩擦係数f)の時間変化率に対する第2指標の時間変化率の相対比(第2指標の時間変化率/第1指標の時間変化率)、及び、第1指標の振幅に対する第2指標の振幅の相対比(第2指標の振幅/第1指標の振幅)は小さくなる方向に変化する。また、境界潤滑が占める割合が極めて小さい混合潤滑から、境界潤滑が占める割合がある程度にまで大きくなる場合には、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比は大きくなる方向に変化する。更に、境界潤滑が占める割合が大きくなると、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比は、再び小さくなる方向に変化する。このように、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、流体潤滑下では潤滑膜(潤滑膜厚さ)の健全性を推定でき、混合潤滑下では混合潤滑に占める境界潤滑の割合を推定できることがわかる。
〔検証2〕
図4は、検証2の要素試験とシミュレーションで用いたスラスト滑り軸受モデルを示す図である。このスラスト滑り軸受モデルは、スラスト軸受45と当該スラスト軸受45に支持された回転ディスク44との間に潤滑剤による潤滑膜46が形成されたものである。要素試験では、スラスト滑り軸受モデルを用いて、回転ディスク44の回転速度を一定とし、温度管理により潤滑剤の粘度μを一定に保ち、軸受への押付荷重Fを増加させながら周期的に変動させたときの摩擦係数f及び押付荷重Fの経時的変化を求めた。なお、回転ディスク44の回転速度は摺動面の摺動速度vと対応する物理量であり、軸受荷重は摺動面の押付荷重Fと対応する物理量である。このシミュレーションの結果を図5Aに示し、要素試験の結果を図5Bに示す。ここでも前記シミュレーションの例と同様に、摩擦係数fが第1指標、押付荷重Fが第2指標である。
図4は、検証2の要素試験とシミュレーションで用いたスラスト滑り軸受モデルを示す図である。このスラスト滑り軸受モデルは、スラスト軸受45と当該スラスト軸受45に支持された回転ディスク44との間に潤滑剤による潤滑膜46が形成されたものである。要素試験では、スラスト滑り軸受モデルを用いて、回転ディスク44の回転速度を一定とし、温度管理により潤滑剤の粘度μを一定に保ち、軸受への押付荷重Fを増加させながら周期的に変動させたときの摩擦係数f及び押付荷重Fの経時的変化を求めた。なお、回転ディスク44の回転速度は摺動面の摺動速度vと対応する物理量であり、軸受荷重は摺動面の押付荷重Fと対応する物理量である。このシミュレーションの結果を図5Aに示し、要素試験の結果を図5Bに示す。ここでも前記シミュレーションの例と同様に、摩擦係数fが第1指標、押付荷重Fが第2指標である。
図5Aの図表(シミュレーション結果)には、摺動面の押付荷重F(軸受荷重)の経時的変化と、摩擦係数fの経時的変化とが表されている。この図表から、流体潤滑下において、押付荷重Fと摩擦係数fとは周期的に変動し、その周期は等しく、且つ、位相差が半周期であることが読み取れる。より詳細には、流体潤滑下において、押付荷重Fが増加する間に摩擦係数fは減少し、押付荷重Fが減少する間に摩擦係数は増加する。即ち、流体潤滑下において、摩擦係数fと押付荷重Fの相関は負の相関を示す。
また、図5Aの図表から、混合潤滑下において、押付荷重Fと摩擦係数fとは周期的に変動し、その周期は等しく、且つ、同位相であることが読み取れる。より詳細には、混合潤滑下において、押付荷重Fが増加する間に摩擦係数fは増加し、押付荷重Fが減少する間に摩擦係数fは減少する。即ち、混合潤滑下において、摩擦係数fと押付荷重Fの相関は正の相関を示す。
図5Bは要素試験の結果の図表である。図5Aのシミュレーション結果と同様に、摩擦係数fと押付荷重Fの相関が、要素試験においても成立することを確認した。なお要素試験においては、流体潤滑では摺動面に摺動痕(摩耗痕)がないことを、更に混合潤滑まで押付荷重Fを増加させた試験条件では、摺動面に残る摺動痕(摩耗痕)を確認することで、実際の摺動状態を判断して、前記シミュレーションの妥当性を確認した。
更に、図5A及び5Bの図表から、以下のことがわかる。即ち、流体潤滑下、且つ、流体潤滑が弱くなる(潤滑膜が薄くなる)方向に物理量S*が経時的に変化する場合は、第1指標(摩擦係数f)の時間変化率に対する第2指標(押付荷重F)の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比は小さくなる方向に変化する。また、境界潤滑が占める割合が極めて小さい混合潤滑から、境界潤滑が占める割合がある程度にまで大きくなる場合には、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比は大きくなる方向に変化する。このように、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、流体潤滑下では潤滑膜(潤滑膜厚さ)の健全性を推定でき、混合潤滑下では混合潤滑に占める境界潤滑の割合を推定できることがわかる。
以上の検証1及び2の結果から、ジャーナル滑り軸受及びスラスト滑り軸受において、摩擦係数fと押付荷重Fの相関は、実質的に同じ傾向を示し、潤滑状態が流体潤滑から混合潤滑に遷移したあと変化することが明らかとなった。ジャーナル滑り軸受及びスラスト滑り軸受における、摩擦係数fと押付荷重Fの相関を表6に示す。

摺動面の押付荷重Fは物理量S*の分母成分であることから、押付荷重Fの時間変化率の正は物理量S*の時間変化率の負と対応し、その逆も同様である。従って、検証1及び2の結果は、表1に示す摩擦係数fと物理量S*の相関と矛盾しない。
〔潤滑状態推定システム50の構成〕
以上に鑑み、本実施形態に係る潤滑状態推定システム50及び方法では、摩擦係数fと物理量S*の相関が正の相関か負の相関であるかに基づいて、摺動面の潤滑状態を推定し、それを摺動面の焼付きの予兆として捉える。潤滑状態の推定には、流体潤滑であるか混合潤滑であるかの推定が含まれ得る。また、潤滑状態の推定には、摩擦係数fと物理量S*の相関が正の相関から負の相関に変化したことに基づいて、潤滑状態が流体潤滑から混合潤滑に遷移したことを推定することが含まれ得る。また、潤滑状態の推定には、流体潤滑及び混合潤滑において、その程度を推定することが含まれ得る。
以上に鑑み、本実施形態に係る潤滑状態推定システム50及び方法では、摩擦係数fと物理量S*の相関が正の相関か負の相関であるかに基づいて、摺動面の潤滑状態を推定し、それを摺動面の焼付きの予兆として捉える。潤滑状態の推定には、流体潤滑であるか混合潤滑であるかの推定が含まれ得る。また、潤滑状態の推定には、摩擦係数fと物理量S*の相関が正の相関から負の相関に変化したことに基づいて、潤滑状態が流体潤滑から混合潤滑に遷移したことを推定することが含まれ得る。また、潤滑状態の推定には、流体潤滑及び混合潤滑において、その程度を推定することが含まれ得る。
図6は、本開示の第1実施形態に係る潤滑状態推定システム50の概略構成を示すブロック図である。図6に示す潤滑状態推定システム50は、第1指標を測定する第1指標測定器51a及び第2指標を測定する第2指標測定器51bを含む指標測定器51と、潤滑状態推定装置53とを含む。
指標測定器51は、第1指標及び前記第2指標、又はそれらの成分となる物理量を測定する少なくとも1種類の測定器を含む。第1指標測定器51aと第2指標測定器51bとは共通の測定器を含んでいてもよい。第1指標測定器51a及び第2指標測定器51bは、測定される物理量に応じて各種の計器から適宜選択される。
第1指標は、相対運動をする2つの物体の摺動面の摩擦係数f、又は、摩擦係数fと相関する指標である。ここで、「摩擦係数fと相関する指標」とは、摩擦係数fと時間変化率の正負が対応する指標である。なお、「時間変化率の正負が対応する」ことには、時間変化率の正負が整合する場合と、時間変化率の正負が逆になる場合とが含まれる。第1指標は、1種類の物理量からなる指標、又は、2種類以上の物理量の組み合わせからなる指標であってよい。第1指標は、時間変化率の正負がわかれば足りるので、定量的且つ正確な値は要求されない。
第2指標は、相対運動をする2つの物体の摺動面の物理量S*、又は、物理量S*と相関する指標である。ここで、「物理量S*と相関する指標」とは、物理量S*と時間変化率の正負が対応する指標である。第2指標の成分には、摺動面に介在する潤滑剤の粘度μ、摺動面の摺動速度v、及び、摺動面の押付荷重F、又は、それらと相関する物理量が含まれてよい。第2指標は、時間変化率の正負がわかれば足りるので、定量的且つ正確な値は要求されない。そこで、潤滑剤の粘度μを潤滑剤の温度で代替したり、摺動面の摺動速度vを回転速度で代替したりしてよい。
潤滑状態推定装置53は、いわゆるコンピュータであって、少なくとも1つのプロセッサと、当該プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備える。メモリには、プロセッサが実行するプログラムの他に、各種固定データ等が記憶されている。プロセッサは、外部装置とのデータ送受信を行う。潤滑状態推定装置53では、メモリに記憶されたプログラム等のソフトウェアをプロセッサが読み出して実行することにより、後述する処理が行われる。なお、潤滑状態推定装置53は単一のコンピュータによる集中制御により各処理を実行してもよいし、複数のコンピュータの協働により各処理を実行してもよい。
以下、潤滑状態推定装置53による潤滑状態推定処理の流れについて説明する。図7は、潤滑状態推定装置53の処理の流れを説明するフローチャートである。図7に示すように、潤滑状態推定装置53は、指標測定器51から第1指標及び第2指標を取得する(ステップS1)。そして、潤滑状態推定装置53は、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関(以下、単に「第1指標と第2指標の相関」と称する)を求める(ステップS2)。
更に、潤滑状態推定装置53は、第1指標と第2指標の相関が、正の相関か負の相関かに基づいて、摺動面の潤滑状態が流体潤滑か混合潤滑かを判断する(ステップS3)。
摺動面の潤滑状態が流体潤滑であれば(ステップS3でYES)、潤滑状態推定装置53は流体潤滑の程度の推定を行う。具体的には、潤滑状態推定装置53は、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方を求める(ステップS4)。潤滑状態推定装置53は、求めた相対比に基づいて、流体潤滑の健全性を評価する(ステップS5)。ここで、潤滑状態推定装置53は、求めた相対比に基づいて潤滑膜厚さを推定し、推定された潤滑膜厚さと所定の閾値とを比較して潤滑膜厚さが閾値以上であれば流体潤滑が健全であると評価する。相対比と潤滑膜厚さとの関係を特定する情報は予め潤滑状態推定装置53に記憶されており、潤滑状態推定装置53はこの情報を用いて相対比から潤滑膜厚さを推定することができる。また、潤滑膜厚さに関する閾値は、摺動面に応じて適宜設定されてよい。
流体潤滑が健全であれば(ステップS5でYES)、処理がS1に戻って繰り返される。流体潤滑が健全でなければ(ステップS5でNO)、潤滑状態推定装置53は接続された不図示の警報装置より注意報を出力して(ステップS6)、処理をステップS1に戻す。なお、この注意報は焼付きの予兆の検知を報知するものではなく、流体潤滑を形成している潤滑膜の厚みが低下している(混合潤滑に近づいている)ことを報知するにすぎないが、作業者は注意報を受けて適切な処置をとることができる。
一方、摺動面の潤滑状態が混合潤滑であれば(ステップS3でNO)、潤滑状態推定装置53は混合潤滑の程度の推定を行う。具体的には、潤滑状態推定装置53は、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方を求める(ステップS11)。そして、潤滑状態推定装置53は、求めた相対比に基づいて、焼付きリスクが低いか否かを判断する(ステップS12)。具体的には、潤滑状態推定装置53は、求めた相対比に基づいて混合潤滑に占める境界潤滑の割合を推定し、境界潤滑の割合と所定の閾値とを比較し、境界潤滑の割合が閾値より大きいときは焼付きリスク高と判断し、境界潤滑の割合が閾値以下のときは焼付きリスク低と判断する。相対比と混合潤滑に占める境界潤滑の割合との関係を特定する情報は予め潤滑状態推定装置53に記憶されており、潤滑状態推定装置53はこの情報を用いて相対比から境界潤滑の割合を推定することができる。また、境界潤滑の割合に関する閾値は、焼付き等が発生しない値であって、且つ、焼付きが発生するまでに十分な時間が確保できるような値が、摺動面に応じて適宜設定されてよい。このように境界潤滑の割合に関する閾値が設定されることで、軽度の混合潤滑では焼付きの予兆が検知されず、誤診断を回避することができる。また、軽度の混合潤滑では焼付きまで十分な余裕があり、直ちに対応する必要がないことがある。そこで、摺動面を含む2つの物体(例えば、軸と軸受など)の運用状態や損傷発生時の影響やなどを考慮して閾値を設定することで、焼付き等を防止するための処理を開始するタイミングを決定すること可能となる。
潤滑状態推定装置53は、焼付きリスク低と判断したときは(ステップS12でYES)、接続された不図示の警報装置より注意報を出力して(ステップS13)、処理をステップS1に戻す。なお、この注意報は焼付きの予兆の検知を報知するものではなく、潤滑状態が混合潤滑にあることを報知するにすぎないが、作業者は注意報を受けて適切な処置をとることができる。
潤滑状態推定装置53は、焼付きリスク高と判断したときは(ステップS12でNO)、それを焼付きの予兆として検知し(ステップS14)、接続された不図示の警報装置より警報を出力する(ステップS15)。この警報は焼付きの予兆の検知を報知するものである。更に、潤滑状態推定装置53は、焼付きの予兆を検知後に、所定の処理を行うように機械を動作させる指令信号を出力したり不図示のモニタに処理の内容を表示出力させたりしてから(ステップS16)、処理を終了してよい。所定の処理には、潤滑剤の追加、押付荷重Fの低減、及び、相対運動の停止のうち少なくとも1つが含まれていてよい。
上記の潤滑状態推定処理の流れは、以下に説明するように変形してもよい。図8は、潤滑状態推定装置53の処理の流れの変形例を説明するフローチャートである。図8に示すように、潤滑状態推定処理の流れの変形例では、ステップS4及びステップS5が省略されて、ステップS3で流体潤滑と判断されれば、処理がS1に戻って繰り返される点、及び、ステップS13が省略されて、ステップS12で焼付きリスク低と判断されれば、処理がS1に戻って繰り返される点で、図7に示す処理の流れと異なる。このような相違点により、図8に示す処理の流れは、図7に示す処理の流れと比較して簡易であり、明らかに混合潤滑が進行しているときにのみ、焼付きの予兆が検知される。
以上に説明した通り、本実施形態に係る潤滑状態推定装置53は、少なくとも1つのプロセッサと、当該プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、プロセッサが、第1指標及び第2指標を取得し、第1指標と第2指標の相関(即ち、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関)に基づいて、摺動面の潤滑状態を推定する。ここで、第1指標は、摺動面の摩擦係数f又は当該摩擦係数fと相関する指標であり、第2指標は、S*=μv/F(但し、μは摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標である。
また、上記構成の潤滑状態推定装置53で実施される潤滑状態推定方法は、第1指標及び第2指標を取得すること、及び、第1指標と第2指標の相関に基づいて、摺動面の潤滑状態を推定することを含む。
前述の通り、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関が、摺動面の潤滑状態が流体潤滑ときと混合潤滑のときとで異なる。このことを利用して、上記潤滑状態推定装置53及び方法では、第1指標の時間変化率の正負と第2指標の時間変化率の正負との相関に基づいて、摺動面の潤滑状態が流体潤滑であるか混合潤滑であるか、また、その遷移を推定することができる。そして、この推定結果を利用して、焼付き等が生じる前にその予兆を捉えることができる。そして、焼付き等の予兆を捉えたタイミングで焼付き等を防止するための処理を行うことによって、焼付き等を未然に防ぐことができる。
更に、上記潤滑状態推定装置53及び方法では、第1指標及び第2指標について時間変化率の正負がわかれば足りるので、第1指標及び第2指標の厳密な値は要求されない。よって、上記潤滑状態推定装置53及び方法によれば、厳密な値を測定することの困難な実機において、相対運動をする2つの物体の摺動面の潤滑状態を推定することができる。
また、本実施形態に係る潤滑状態推定装置53では、プロセッサは、摺動面が流体潤滑であると推定したときに、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、摺動面の流体潤滑の健全性を評価する。
更に、本実施形態に係る潤滑状態推定装置53では、プロセッサが、摺動面が混合潤滑であると推定したときに、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、摺動面の混合潤滑に占める境界潤滑の割合を推定する。
同様に、本実施形態に係る潤滑状態推定方法では、混合潤滑下において、摺動面が流体潤滑と推定されたときに、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、摺動面の流体潤滑の健全性を評価することを更に含む。
更に、本実施形態に係る潤滑状態推定方法では、摺動面が混合潤滑と推定されたときに、第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第2指標が周期的に変化する場合における第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、摺動面の混合潤滑に占める境界潤滑の割合を推定することを、更に含む。
第1指標の時間変化率に対する第2指標の時間変化率の相対比、及び、第1指標の振幅に対する第2指標の振幅の相対比の少なくとも一方に基づいて、流体潤滑下では潤滑膜(潤滑膜厚さ)の健全性を評価でき、混合潤滑下では混合潤滑に占める境界潤滑の割合を推定できる。よって、上記相対比に基づいて摺動面の流体潤滑の健全性及び混合潤滑に占める境界潤滑の割合を推定することによって、摺動面を含む2つの物体(例えば、軸と軸受など)の運用状態や損傷発生時の影響やなどを考慮して、焼付き等を防止するための処理を開始するタイミングを決定すること可能となる。
〔第2実施形態〕
続いて、本開示の第2実施形態を説明する。
続いて、本開示の第2実施形態を説明する。
図9は、図1に示すストライベック線図を粘度μおよび摺動速度vが一定の条件で、T-F線図に変換したものである。T-F線図では、縦軸が軸トルクTを表し、横軸が押付荷重Fを表す。このT-F線図には、軸トルクTと押付荷重Fとの関係を表すT-F線が描かれている。潤滑状態が流体潤滑であるとき、T-F線の接線の傾きは押付荷重Fの増加に対して減少又は概ね一定であり(図9及び表7を参照)、T-F線の接線の切片は0又は正の値であって押付荷重Fの増加に従って増加する。流体潤滑から混合潤滑の遷移領域では、T-F線の接線の傾きが増加し、切片が正から負に減少する。潤滑状態が混合潤滑であるとき、T-F線の接線の傾きは押付荷重Fの増加(即ち、混合潤滑における境界潤滑の割合の増加)に従って大きくなり、T-F線の接線の切片は負の値であって押付荷重Fの増加に従って減少する。流体潤滑下では、押付荷重Fの増加に従って、潤滑膜の厚みが低下する。また、混合潤滑下では、押付荷重Fの増加に従って、混合潤滑における境界潤滑の割合が増加する。このようなT-F線の特性を次表7に表す。

回転ディスク44の軸の半径r、摩擦係数f、軸トルクT、及び、押付荷重Fは、f=T/(Fr)の関係で表され、押付荷重Fと軸トルクTは常に正の相関がある。そのため、T-F線の接線の傾きは常に正になるが、押付荷重Fの増加によって傾きの大きさが変化する。表7のようなT-F線の接線における傾きと切片の変化を検証するために、次に示す検証3を行った。
〔検証3〕
検証3の要素試験で用いたスラスト滑り軸受モデルは、検証2で用いたものと同じである(図4、参照)。要素試験では、スラスト滑り軸受モデルを用いて、回転ディスク44の回転速度を一定とし、温度管理により潤滑剤の粘度μを一定に保ち、軸受への押付荷重Fを増加させながら周期的に変動させたときの摩擦係数f及び押付荷重Fの経時的変化を求めた。この要素試験の結果を図10に示す。
検証3の要素試験で用いたスラスト滑り軸受モデルは、検証2で用いたものと同じである(図4、参照)。要素試験では、スラスト滑り軸受モデルを用いて、回転ディスク44の回転速度を一定とし、温度管理により潤滑剤の粘度μを一定に保ち、軸受への押付荷重Fを増加させながら周期的に変動させたときの摩擦係数f及び押付荷重Fの経時的変化を求めた。この要素試験の結果を図10に示す。
図10の図表では、縦軸がスラスト軸受45の摺動抗力T’を表し、横軸が押付荷重Fを表す。図11は、図10の図表に描かれた線(T’-F線)の接線の傾きの変化を表す図表であり、図12は、図10の図表に描かれた線(T’-F線)の接線の切片の値の変化を表す図表である。
図10~12から、検証3で得られたT’-F線は、図9に示す理想的なT-F線と整合していることがわかる。つまり、潤滑状態が流体潤滑であるとき、T’-F線の接線の傾きは押付荷重Fの増加に対して概ね一定又は減少しており、T’-F線の接線の切片は0又は正の値であって押付荷重Fの増加に従って一定又は増加する。潤滑状態が混合潤滑であるとき、T’-F線の接線の傾きは押付荷重Fの増加に従ってく大きくなり、T’-F線の接線の切片は負の値であって押付荷重Fの増加に従って著しく減少する。このように、軸トルクTと相関する指標(スラスト軸受45の摺動抗力)と押付荷重Fの関係が、要素試験においても成立することを確認した。
本実施形態に係る潤滑状態推定システム50Aは、上記のようなT-F線の特性を利用して、回転軸と軸受との摺動面の潤滑状態を推定するものである。図13に示すように、本実施形態に係る潤滑状態推定システム50Aは、第3指標を測定する少なくとも1つの第3指標測定器51c、及び、第4指標を測定する少なくとも1つの第4指標測定器51dを含む指標測定器51と、指標測定器51から第3指標及び第4指標を取得し、これらを用いて摺動面の潤滑状態を推定する潤滑状態推定装置53とを備える。第3指標測定器51c及び第4指標測定器51dは、測定される物理量に応じて各種の計器から適宜選択される。第3指標測定器51cと第4指標測定器51dとは共通の測定器を含んでいてもよい。
第3指標T’は、回転軸の軸トルクT又は軸トルクTと相関する指標である。ここで、「軸トルクTと相関する指標」とは、軸トルクTと時間変化率の正負が対応する指標である。軸トルクTと相関する指標には、例えば、回転軸を回転駆動する駆動軸の摺動抗力T’、軸動力などがある。なお、軸トルクTと摺動抗力T’と摺動半径rとの関係は、T’=T/rで表されることから、軸トルクTと摺動抗力T’とには正の相関がある。
第4指標F’は、回転軸と軸受の摺動面の押付荷重F又は押付荷重Fと相関する指標である。ここで、「押付荷重Fと相関する指標」とは、が押付荷重Fと時間変化率の正負が対応する指標である。押付荷重Fと相関する指標には、例えば、押付荷重(軸受荷重)の制御値、押付荷重Fを受ける油圧機器の油圧値、回転軸を駆動する駆動軸に回転動力を与えるモータの駆動電流値などがある。
潤滑状態推定装置53は、第3指標測定器51c及び第4指標測定器51dから第3指標T’及び第4指標F’を取得して、縦軸が第3指標T’を表し横軸が第4指標F’を表すT’-F’線図に取得した第3指標T’及び第4指標F’をプロットすることを少なくとも2回以上繰り返し、図表に表れるT’-F’線の接線の傾き及び接線の切片を求める。そして、潤滑状態推定装置53は、T’-F’線の接線の傾き及び接線の切片の組み合わせに基づいて、摺動面の潤滑状態を推定する。具体的には、流体潤滑であるか混合潤滑であるかを推定する。更に、流体潤滑と推定したときに流体潤滑の健全性を評価したり、混合潤滑と推定したときに混合潤滑に占める境界潤滑の割合を推定したりしてもよい。
図14は、潤滑状態推定装置53の処理の流れを説明するフローチャートである。図11に示すように、潤滑状態推定装置53は、指標測定器51から第3指標及び第4指標(又は、それらの成分)を取得する(ステップS21)。そして、潤滑状態推定装置53は、縦軸が第3指標T’を表し、横軸が第4指標F’を表す両対数グラフに、第3指標T’の測定値と第4指標F’の測定値をプロットする(ステップS22)。ステップS21とステップS22とを少なくとも2回繰り返すことにより、第3指標-第4指標線(T’-F’線)を作成することができる。図15に、第3指標-第4指標線図の一例を示す。
潤滑状態推定装置53は、T’-F’線の接線の傾きと接線の切片とを求める(ステップS23)。潤滑状態推定装置53は、T’-F’線の接線の傾き及び接線の切片の組み合わせに基づいて、摺動面の潤滑状態が流体潤滑であるか否かを判断する(ステップS24)。摺動面の潤滑状態が流体潤滑であるか否かを判断には、潤滑状態推定装置53に予め記憶された表7に示すようなT’-F’線と潤滑状態との関係が利用される。
摺動面の潤滑状態が流体潤滑であれば(ステップS24でYES)、潤滑状態推定装置53は流体潤滑の程度の推定を行う。具体的には、潤滑状態推定装置53は、T’-F’線の接線の切片の値に基づいて、流体潤滑の健全性を評価する(ステップS25)。ここで、潤滑状態推定装置53は接線の切片の値から潤滑膜厚さを推定し、推定された潤滑膜厚さと所定の閾値とを比較して潤滑膜厚さが閾値以上であれば流体潤滑が健全であると評価する。接線の切片の値と潤滑膜厚さとの関係を特定する情報は、予め潤滑状態推定装置53に記憶されており、潤滑状態推定装置53はこの情報を用いて接線の切片の値から潤滑膜厚さを推定することができる。また、潤滑膜厚さに関する閾値は、摺動面に応じて適宜設定されてよい。
流体潤滑が健全であれば(ステップS25でYES)、処理がS21に戻って繰り返される。流体潤滑が健全でなければ(ステップS25でNO)、潤滑状態推定装置53は接続された不図示の警報装置より注意報を出力して(ステップS26)、処理をステップS21に戻す。なお、この注意報は焼付きの予兆の検知を報知するものではなく、流体潤滑を形成している潤滑膜の厚みが低下していることを報知するにすぎないが、作業者は注意報を受けて必要に応じて適切な処置をとることができる。
一方、摺動面の潤滑状態が混合潤滑であれば(ステップS24でNO)、潤滑状態推定装置53は混合潤滑の程度の推定を行う。具体的には、潤滑状態推定装置53は、T-F線の接線の切片の値に基づいて、焼付きリスクが低いか否かを判断する(ステップS27)。具体的には、潤滑状態推定装置53は、接線の切片の値に基づいて混合潤滑に占める境界潤滑の割合を推定し、境界潤滑の割合と所定の閾値とを比較し、境界潤滑の割合が閾値より大きいときは焼付きリスク高と判断し、境界潤滑の割合が閾値以下のときは焼付きリスク低と判断する。接線の切片の値と混合潤滑に占める境界潤滑の割合との関係を特定する情報は予め潤滑状態推定装置53に記憶されており、潤滑状態推定装置53はこの情報を用いて接線の切片の値から境界潤滑の割合を推定することができる。また、境界潤滑の割合に関する閾値は、焼付き等が発生しない値であって、且つ、焼付きが発生するまでに十分な時間が確保できるような値が、摺動面に応じて適宜設定されてよい。このように境界潤滑の割合に関する閾値が設定されることで、軽度の混合潤滑では焼付きの予兆が検知されず、誤診断を回避することができる。また、軽度の混合潤滑では焼付きまで十分な余裕があり、直ちに対応する必要がないことがある。そこで、摺動面を含む2つの物体(例えば、軸と軸受など)の運用状態や損傷発生時の影響やなどを考慮して閾値を設定することで、焼付き等を防止するための処理を開始するタイミングを決定すること可能となる。
潤滑状態推定装置53は、焼付きリスク低と判断したときは(ステップS27でYES)、接続された不図示の警報装置より注意報を出力して(ステップS28)、処理をステップS21に戻す。なお、この注意報は焼付きの予兆の検知を報知するものではなく、潤滑状態が混合潤滑にあることを報知するにすぎないが、作業者は注意報を受けて適切な処置をとることができる。
潤滑状態推定装置53は、焼付きリスク高と判断したときは(ステップS27でNO)、これを焼付きの予兆として検知し(ステップS29)、接続された不図示の警報装置より警報を出力する(ステップS30)。この警報は焼付きの予兆の検知を報知するものである。更に、潤滑状態推定装置53は、焼付きの予兆を検知後に、所定の焼付き防止のための処理を行うように機械を動作させる指令信号を出力したり不図示のモニタに処理の内容を表示出力させたりしてよい(ステップS31)。所定の処理には、潤滑剤の追加減、押付荷重Fの低減、及び、回転運動の停止のうち少なくとも1つが含まれていてよい。
以上に説明した通り、本実施形態に係る潤滑状態推定装置53は、回転軸と軸受との摺動面の潤滑状態を推定するものであって、少なくとも1つのプロセッサと、当該プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標T’とし、摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標F’とし、プロセッサが、第3指標T’及び第4指標F’を取得し、縦軸が第3指標T’を表し横軸が第4指標F’を表す図表に取得した第3指標T’及び第4指標F’をプロットすることを少なくとも2回以上繰り返し、図表に表れる線の接線の傾き及び切片を取得し、当該接線の傾き及び切片の組み合わせに基づいて摺動面の潤滑状態を推定する。潤滑状態を推定することには、流体潤滑であるか混合潤滑であるかを推定すること、流体潤滑と推定したときに流体潤滑の健全性を評価すること、及び、混合潤滑と推定したときに混合潤滑に占める境界潤滑の割合を推定することの、少なくとも1つが含まれてよい。
また、本実施形態に係る潤滑状態推定方法は、回転軸と軸受との摺動面の潤滑状態を推定する潤滑状態推定方法であって、回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標T’とし、摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標F’とし、第3指標T’及び第4指標F’を取得すること、及び、縦軸が第3指標T’を表し横軸が第4指標F’を表す図表に取得した第3指標T’及び第4指標F’をプロットすることを少なくとも2回以上繰り返し、図表に表れる線(T-F線)の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて、摺動面の潤滑状態を推定することを含む。
上記潤滑状態推定装置53及び方法によれば、上記T’-F’線の接線の傾き及び接線の切片に基づいて、摺動面の潤滑状態を推定して、焼付き等が生じる前にその予兆を捉えることができる。そして、焼付き等の予兆を捉えたタイミングで焼付き等を防止するための処理を行うことによって、焼付き等を未然に防ぐことができる。
更に、上記潤滑状態推定装置53及び方法では、T-F線の接線の傾きの正負と、T-F線の接線の切片の正負とがわかれば足りるので、第3指標及び第4指標の厳密な値は要求されない。よって、上記潤滑状態推定装置53及び方法によれば、厳密な値を測定することの困難な実機において、回転軸と軸受との摺動面の潤滑状態を推定することができる。また、流体潤滑と推定したときに流体潤滑の健全性を評価し、混合潤滑と推定したときに混合潤滑に占める境界潤滑の割合を推定することができる。
〔実施例1〕
上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50Aは、例えば、滑り軸受装置60に適用することができる。図16に例示される滑り軸受装置60は、潤滑膜63を介して回転軸61を支持する軸受部材62と、回転軸61及び軸受部材62の摺動面の潤滑状態を推定する潤滑状態推定システム50(及び/又は潤滑状態推定システム50A)とを、備える。なお、図16に例示される滑り軸受装置60はジャーナル滑り軸であるが、スラスト滑り軸受であってもよい。
上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50Aは、例えば、滑り軸受装置60に適用することができる。図16に例示される滑り軸受装置60は、潤滑膜63を介して回転軸61を支持する軸受部材62と、回転軸61及び軸受部材62の摺動面の潤滑状態を推定する潤滑状態推定システム50(及び/又は潤滑状態推定システム50A)とを、備える。なお、図16に例示される滑り軸受装置60はジャーナル滑り軸であるが、スラスト滑り軸受であってもよい。
〔実施例2〕
上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50Aは、例えば、一組の摺動部材66,67を含む機械装置65に適用することができる。図17に例示される機械装置65は、潤滑膜68を介して接触しながら相対運動する一組の摺動部材66,67と、一組の摺動部材66,67の摺動面の潤滑状態を推定する潤滑状態推定システム50(及び/又は潤滑状態推定システム50A)とを、備える。
上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50Aは、例えば、一組の摺動部材66,67を含む機械装置65に適用することができる。図17に例示される機械装置65は、潤滑膜68を介して接触しながら相対運動する一組の摺動部材66,67と、一組の摺動部材66,67の摺動面の潤滑状態を推定する潤滑状態推定システム50(及び/又は潤滑状態推定システム50A)とを、備える。
上記実施例1,2に示すように、潤滑状態推定システム50,50Aは、滑り軸受装置60に限定されず、曲線運動、直線運動、又は往復運動を行う2つの物体の摺動面の潤滑状態を推定するために広く利用できる。
〔実施例3〕
本実施例は、上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50A及び方法を旋動式破砕機100に適用させた実機模擬試験である。図18は、実機模擬試験で用いた旋動式破砕機100の概略構成を示す図である。図18に示す旋動式破砕機100は、フレーム31,32の内部に形成された破砕室16に回転可能に設けられた主軸5を備えたジャイレトリクラッシャ又はコーンクラッシャであって、潤滑状態推定システム50を除いた破砕機100自体の構成は公知である。
本実施例は、上記実施形態1及び実施形態2に係る潤滑状態推定システム50,50A及び方法を旋動式破砕機100に適用させた実機模擬試験である。図18は、実機模擬試験で用いた旋動式破砕機100の概略構成を示す図である。図18に示す旋動式破砕機100は、フレーム31,32の内部に形成された破砕室16に回転可能に設けられた主軸5を備えたジャイレトリクラッシャ又はコーンクラッシャであって、潤滑状態推定システム50を除いた破砕機100自体の構成は公知である。
旋動式破砕機100は、上部フレーム31と当該上部フレーム31に連結された下部フレーム32で形成された内部空間の中央部に、中心軸が破砕機100の中心軸に対して傾斜して配置された主軸5が設けられている。
主軸5の下部は、偏心スリーブ4に回転自在に嵌挿されている。偏心スリーブ4は、下部フレーム32に形成されたボス7に回転自在に嵌挿されている。偏心スリーブ4の下部は、下部フレーム32に設けられたスラスト滑り軸受23に支持されている。主軸5の下端は、主軸昇降用油圧シリンダ6のピストンに設けられた主軸スラスト軸受2に支持されている。主軸5の上端は、上部フレーム31の上端に取り付けられたスパイダ18に設けられた上部軸受17に、回転自在に支持されている。
偏心スリーブ4及びボス7の上方であって、円筒形状の仕切板24の内周側に油圧室27が形成されている。主軸5の外周面と偏心スリーブ4の内周面との間、及び、偏心スリーブ4の外周面とボス7の内周面との間に、潤滑剤が供給される。以下、主軸5の外周面と偏心スリーブ4の内周面との間に形成されたジャーナル滑り軸受を「主軸軸受10」と称し、偏心スリーブ4の外周面とボス7の内周面との間に形成されたジャーナル滑り軸受を「スリーブ軸受11」と称する。そして、主軸軸受10及びスリーブ軸受11により形成された多重軸受を「下部軸受15」と称する。
主軸5の上部は、外周面が截頭円錐面を形成するマントルコア12を構成している。マントルコア12の外側には、外表面が截頭円錐面を形成するマントル13が取り付けられている。上部フレーム31の内面には、コンケーブ14が設けられている。コンケーブ14の内表面とマントル13の外表面とにより、鉛直断面が楔状をなす破砕室16が形成されている。
機外に設けられた駆動モータ8によって駆動される駆動軸8aから偏心スリーブ4へ、プーリ22、横軸、及びベベルギア19を含む動力伝達機構20を介して動力が伝達される。偏心スリーブ4が回転すると、主軸5が上部フレーム31に対して偏心旋回運動、いわゆる歳差運動を行う。これにより、マントル13の外表面とコンケーブ14の内表面との距離が主軸5の旋回位置に応じて変化する。破砕室16内に落下してきた被破砕物は、コンケーブ14とマントル13との間で破砕されて、下部フレーム32の下方から破砕品として回収される。
上記構成の旋動式破砕機100は、主軸昇降用油圧シリンダ6のシリンダ圧力を測定するシリンダ圧力測定器55と、駆動モータ8の駆動軸8aの軸動力(出力)を測定する軸動力測定器56と、潤滑状態推定装置53とを含む潤滑状態推定システム50(及び/又は潤滑状態推定システム50A)を備える。シリンダ圧力測定器55は、主軸昇降用油圧シリンダ6に設けられた油圧センサであって良い。また、軸動力測定器56は、駆動モータ8に設けられた動力計又はトルクセンサであってよい。シリンダ圧力測定器55及び軸動力測定器56は、指標測定器51に相当する。
旋動式破砕機100の下部軸受15では、運転中に摺動面の摩擦係数fや潤滑膜の粘度μなどを精密に計測することは困難である。そこで、下部軸受15における摺動面の摩擦係数fと相関する第1指標として{軸動力/シリンダ圧力}を用い、下部軸受15における物理量S*と相関する第2指標として{シリンダ圧力}を用いた。
下部軸受15の損失は、{摩擦係数f×シリンダ圧力×係数}で表される。旋動式破砕機100の負荷運転中のエネルギー収支を概算すると、駆動軸8aの軸動力と、破砕仕事、下部軸受15の損失、動力伝達機構20の伝達損失、駆動モータ8の機械的損失、及び、下部軸受15を除く軸受の損失の和とが釣り合う。加えて、旋動式破砕機100では、主軸5の回転速度は概ね一定に保持される。負荷は十分に大きく、急峻な負荷変動を無視できる条件下では、下部軸受15の摩擦係数fは{軸動力/シリンダ圧力}と相関する。以上から、下部軸受15の摩擦係数fと相関する第1指標として{軸動力/シリンダ圧力}を用いることができる。ここで、軸動力に代えて軸動力と相関する指標を用いてもよいし、シリンダ圧力に代えてシリンダ圧力と相関する指標を用いてもよい。
また、下部軸受15の物理量S*の時間変化率の正負と、下部軸受15の軸受荷重(即ち、摺動面の押付荷重F)の時間変化率の正負とは対応する。下部軸受15の軸受荷重は{シリンダ圧力×係数}で表される。以上から、物理量S*と相関する第2指標として{シリンダ圧力}を用いることができる。ここで、シリンダ圧力に代えてシリンダ圧力と相関する指標を用いてもよい。
上記構成の旋動式破砕機100の下部軸受15において、主軸5は自転しないものと仮定し、偏心スリーブ4の回転速度を一定とし、潤滑剤の粘度μを温度の上昇に伴って増加させ、破砕荷重を準定常的に変動させる条件で、偏心スリーブ4を回転させたときの第1指標と第2指標の経時的変化をシミュレーションで求めた。そのシミュレーション結果が図19に示されている。
図19の図表では、第1指標(=軸動力/シリンダ圧力)と第2指標(=シリンダ圧力)の経時的変化が表されている。この図表の縦軸が第1指標又は第2指標を表し、横軸が経過時間を表す。この図表において、第1指標と第2指標の相関は、流体潤滑下では負の相関を示すが、やがて或るタイミングで正の相関に変化する。このようなシミュレーション結果によれば、旋動式破砕機100が備える潤滑状態推定システム50では、第1指標と第2指標の相関が負の相関から正の相関に変化したタイミングで、潤滑状態が流体潤滑から混合潤滑へ遷移したことを検知することができる。
以上に説明した通り、本実施例に係る旋動式破砕機100は、コンケーブ14と、コンケーブ14の内部に配置された主軸5と、主軸5に設けられたマントル13と、主軸5の下部が回転自在に挿入された偏心スリーブ4と、偏心スリーブ4が回転自在に挿入されたボス7と、偏心スリーブ4を動力伝達機構20を介して回転駆動する駆動軸8aと、駆動軸8aを回転駆動する駆動モータ8と、主軸5を昇降可能に支持する油圧シリンダ6と、少なくとも1つの滑り軸受装置と、滑り軸受装置において摺動面の潤滑状態を推定する潤滑状態推定システム50,50Aとを備える。潤滑状態推定システム50,50Aは、第1実施形態及び第2実施形態に係る潤滑状態推定システム50,50Aのうち少なくとも1つが旋動式破砕機100に適用されてよい。
本実施例に係る潤滑状態推定システム50,50Aは、主軸5と偏心スリーブ4との間に形成されたジャーナル滑り軸受(主軸軸受10)、及び、偏心スリーブ4とボス7との間に形成されたジャーナル滑り軸受(スリーブ軸受11)からなる二重軸受(下部軸受15)において、摺動面の潤滑状態を推定する。
本実施例に係る潤滑状態推定システム50,50Aは、下部軸受15の摺動面の潤滑状態を推定するが、潤滑状態推定システム50,50Aは旋動式破砕機100が備える他の摺動面の潤滑状態を推定するように構成されてもよい。即ち、潤滑状態推定システム50,50Aは、主軸軸受10、スリーブ軸受11、及び、主軸5と油圧シリンダ6との間に形成された主軸スラスト軸受2、偏心スリーブ4のスラスト滑り軸受23、主軸5の上部を支持するジャーナル滑り軸受(上部軸受17)のうち少なくとも一つの滑り軸受において摺動面の潤滑状態を推定するように構成されてよい。
また、本実施例に係る旋動式破砕機100では、潤滑状態推定システム50,50Aは指標測定器51として、油圧シリンダ6のシリンダ圧力を測定するシリンダ圧力測定器55、及び、駆動モータ8の軸動力を測定する軸動力測定器56を含む。シリンダ圧力測定器55は、第1指標(fに相関)、第2指標(S*に相関)、第4指標(Fに相関)の指標測定器に含まれる。また、軸動力測定器56は、第1指標(fに相関)、第3指標(Tに相関)の指標測定器に含まれる。
そして、潤滑状態推定システム50は、偏心スリーブ4の回転速度と潤滑油の粘度を一定と仮定して、{軸動力又は軸動力と相関する指標/シリンダ圧力又はシリンダ圧力と相関する指標}に相関する関数を第1指標とし、{シリンダ圧力又はシリンダ圧力と相関する指標}に相関する関数を第2指標として、これらの指標を摺動面の潤滑状態の推定に用いる。
また、潤滑状態推定システム50Aは、偏心スリーブ4の回転速度と潤滑油の粘度を一定と仮定して、{軸動力又は軸動力と相関する指標}に相関する関数を第3指標とし、{シリンダ圧力又はシリンダ圧力と相関する指標}に相関する関数を第4指標として、これらの指標を摺動面の潤滑状態の推定に用いる。
このように、本実施例に係る旋動式破砕機100では、旋動式破砕機100の運転中に測定が比較的に容易なプロセスデータを利用して第1指標、第2指標、第3指標、及び第4指標が得られるので、潤滑状態推定システム50,50Aを旋動式破砕機100に容易に適用することができる。また、潤滑状態推定システム50,50Aによって、下部軸受15などの軸受の潤滑状態を定常的且つ継続的に推定することができるので、軸受の潤滑状態に加えて軸受の経年変化を推定することができる。
なお、上記実施例では、旋動式破砕機100の軸動力とシリンダ圧力とを測定し、軸動力及びシリンダ圧力の測定値を推定対象の滑り軸受(本実施例では下部軸受15)の潤滑状態の推定に用いるが、第1~4指標として利用できるその他の物理量が用いられてもよい。
第1指標は、推定対象の滑り軸受の摩擦係数fと相関する物理量であれば、仕事や、軸受損失、その他損失などを含む計測値であってもよい。第2指標は、推定対象の物理量S*と相関する指標であれば、仕事や、軸受損失、その他損失などを含む計測値であってもよい。第3指標は、軸トルクと相関する指標であれば、仕事や、軸受損失、その他損失などを含む計測値であってもよい。第4指標は、軸受摺動面の荷重(押付荷重F)と相関する指標であれば、仕事や、軸受損失、その他損失などを含む計測値であってもよい。例えば、駆動モータ8の軸動力に代えて、主軸5の軸トルクと回転速度から求まる軸動力、駆動モータ8に与える電流と電圧から求まるモータ動力などが用いられてよい。軸トルクは、主軸5の歪みや主軸5の応力で代用されてよい。駆動モータ8の回転速度が概ね一定であれば、駆動軸8aの軸動力に代えて、駆動モータ8の出力トルク(駆動軸8aの軸トルク)が用いられてよい。また、例えば、シリンダ圧力に代えて、シリンダの変位量が用いられてよい。
〔第3実施形態〕
続いて、本開示の第3実施形態を説明する。なお、本実施形態の説明においては、前述の実施形態と同一又は類似の部材には図面に同一の符号を付し、説明を省略する。
続いて、本開示の第3実施形態を説明する。なお、本実施形態の説明においては、前述の実施形態と同一又は類似の部材には図面に同一の符号を付し、説明を省略する。
図18に示すように、前述の旋動式破砕機100において、1本の主軸5は、ジャーナル滑り軸受である下部軸受15と、スラスト滑り軸受である主軸スラスト軸受2との両軸受に支持されている。下部軸受15は正常な潤滑状態が流体潤滑である、所謂、「流体潤滑軸受」である。流体潤滑軸受では、潤滑状態が、流体潤滑から混合潤滑を経て境界潤滑に遷移する。また、主軸スラスト軸受2は正常な潤滑状態が境界潤滑である、所謂、「境界潤滑軸受」である。境界潤滑軸受では、局部的な過熱等によって油膜の破損が生じると、金属同士が接触するようになり、金属表面が部分的に融着する。融着した金属が強制的に引き離されると、引っ掻き傷のような痕跡が生じる。つまり、境界潤滑軸受では、油膜が破損すると、スカッフィング現象が生じる。
旋動式破砕機100では、粘度μおよび摺動速度vが一定と仮定することができる。このような条件下で、{駆動軸8aの軸動力(又は当該軸動力と相関する指標)/油圧シリンダ6のシリンダ圧力(又は当該シリンダ圧力と相関する指標)}を第5指標とする。また、上記条件下で、{1/油圧シリンダ6のシリンダ圧力(又は当該シリンダ圧力と相関する指標)}を第6指標とする。
図20Aは、下部軸受15の第5指標-第6指標線図である。第5指標-第6指標線図は、縦軸が第5指標を表し、横軸が第6指標を表す両対数グラフである。下部軸受15の潤滑状態が流体潤滑であるとき、第5指標-第6指標線の接線の傾き(つまり、第6指標に対する第5指標の変化率)は正である。下部軸受15の潤滑状態が混合潤滑であるとき、第5指標-第6指標線の接線の傾きは負である。
図20Bは、主軸スラスト軸受2の第5指標-第6指標線図である。図20Aと図20Bの横軸のスケールは対応している。主軸スラスト軸受2の潤滑状態が境界潤滑であるとき、第5指標-第6指標線の接線の傾きはほぼ0である。下部軸受15の潤滑状態が境界潤滑からスカッフィング現象が生じる状態となったとき、第5指標-第6指標線の接線の傾きは負である。図20と図21とを比較してわかるように、下部軸受15の潤滑状態が混合潤滑であるときの第5指標-第6指標線の接線の傾きよりも、主軸スラスト軸受2の潤滑状態がスカッフィング現象発生状態であるときの第5指標-第6指標線の接線の傾きの方が急峻である。換言すれば、下部軸受15の潤滑状態が混合潤滑であるとき第6指標に対する第5指標の変化率R1は、主軸スラスト軸受2の潤滑状態が混合潤滑であるとき第6指標に対する第5指標の変化率R2と比較して大きい。なお、R1及びR2はいずれも負の値である。
以上の現象に鑑み、図21に示すように、本実施形態に係る潤滑状態推定システム50Bは、第5指標を測定する少なくとも1つの第5指標測定器51eと、第6指標を測定する少なくとも1つの第6指標測定器51fと、第5指標及び第6指標の測定値を取得し、第6指標に対する第5指標の変化率Rに基づいて下部軸受15(流体潤滑軸受)及び主軸スラスト軸受2(境界潤滑軸受)の潤滑状態を推定する潤滑状態推定装置53とを備える。第5指標測定器51eには、第1及び第2実施形態の実施例3で説明した軸動力測定器56及びシリンダ圧力測定器55が含まれ得る。また、第6指標測定器51fには、第1及び第2実施形態の実施例3で説明したシリンダ圧力測定器55が含まれ得る。
図22は、潤滑状態推定装置53の処理の流れを説明するフローチャートである。図22に示すように、潤滑状態推定装置53は、第5指標測定器51eから第5指標の測定値を取得し、第6指標測定器51fから第6指標の測定値を取得する(ステップS51)。潤滑状態推定装置53は、第6指標に対する第5指標の変化率Rを求める(ステップS52)。潤滑状態推定装置53は、変化率Rが正の値であれば(ステップS53でYES)、下部軸受15及び主軸スラスト軸受2の潤滑状態が正常であるとして、処理をステップS51に戻る。
潤滑状態推定装置53は、変化率Rが負の値であれば(ステップS53でYES)、変化率Rと所定の第1閾値α1とを比較する(ステップS54)。第1閾値α1は、0よりも小さい値である。潤滑状態推定装置53は、変化率Rが第1閾値α1以下であるときに(ステップS54でYES)、主軸スラスト軸受2(境界潤滑軸受)でスカッフィング現象が生じていることを推定して、不図示の警報装置より主軸スラスト軸受2の異常を報知する警報を出力する(ステップS55)。
ステップS54で変化率Rが第1閾値α1よりも大きければ(ステップS54でNO)、潤滑状態推定装置53は変化率Rと所定の第2閾値α2とを比較する(ステップS56)。第2閾値α2は、第1閾値α1よりも大きく、且つ、0よりも小さい値である(0>α2>α1)。潤滑状態推定装置53は、変化率Rが、第1閾値α1より大きく、且つ、第2閾値α2以下であるときに(ステップS56でYES)、下部軸受15(流体潤滑軸受)で混合潤滑に占める境界潤滑の割合が所定割合以上となったことを推定して、不図示の警報装置より下部軸受15の異常を報知する警報を出力する(ステップS57)。ここで「所定割合」は、摺動面の焼付きが生じるに至らないが、摺動を継続すると近い未来に摺動面の焼付きが生じ得るような値である。
ステップS56で変化率Rが第2閾値α2よりも大きければ(ステップS56でNO)、潤滑状態推定装置53は、不図示の警報装置より下部軸受15の潤滑状態に対し注意報を出力し(ステップS58)、処理をステップS51へ戻す。この注意報では、潤滑膜の厚みが低下していることを注意喚起するにすぎないが、作業者は注意報を受けて適切な処置をとることができる。
以上に説明した通り、本実施形態に係る旋動式破砕機100は、コンケーブ14と、コンケーブ14の内部に配置された主軸5と、主軸5に設けられたマントル13と、主軸5の下部が回転自在に挿入された偏心スリーブ4と、偏心スリーブ4が回転自在に挿入されたボス7と、偏心スリーブ4を回転駆動する駆動軸8aと、駆動軸8aを回転駆動する駆動モータ8と、主軸5を昇降可能に支持する油圧シリンダ6と、主軸5と偏心スリーブ4との間に形成された第1流体潤滑軸受である主軸軸受10、及び、偏心スリーブ4とボス7との間に形成された第2流体潤滑軸受であるスリーブ軸受11からなる下部軸受15と、主軸5と油圧シリンダ6との間に形成された境界潤滑軸受である主軸スラスト軸受2と、第5指標を測定する少なくとも1つの第5指標測定器51eと、第6指標を測定する少なくとも1つの第6指標測定器51fと、第6指標に対する第5指標の変化率Rに基づいて第1流体潤滑軸受、第2流体潤滑軸受及び境界潤滑軸受の潤滑状態を推定する潤滑状態推定装置53とを備える。
また、本実施形態に係る旋動式破砕機100の潤滑状態推定方法は、第5指標及び第6指標を測定すること、及び、第6指標に対する第5指標の変化率に基づいて第1流体潤滑軸受、第2流体潤滑軸受及び境界潤滑軸受の潤滑状態を推定することを含む。
本実施形態において、潤滑状態推定装置53は、変化率Rが0より小さい所定の第1閾値α1以下であるときに、主軸スラスト軸受2(境界潤滑軸受)でスカッフィング現象が生じていることを推定する。同様に、上記潤滑状態推定方法は、潤滑状態を推定するステップが、変化率Rが0より小さい所定の第1閾値α1以下であるときに、主軸スラスト軸受2(境界潤滑軸受)でスカッフィング現象が生じていることを推定することを含む。
本実施形態において、潤滑状態推定装置53は、変化率Rが、第1閾値α1より大きく、且つ、0より小さい所定の第2閾値α2以下であるときに、下部軸受15(第1流体潤滑軸受及び第2流体潤滑軸受のうち少なくとも一方)で混合潤滑に占める境界潤滑の割合が所定割合以上となったことを推定する。同様に、上記潤滑状態推定方法は、潤滑状態を推定することが、変化率Rが0より小さい所定の第1閾値α1より大きく、且つ、0より小さい所定の第2閾値α2以下であるときに、下部軸受15(第1流体潤滑軸受及び第2流体潤滑軸受のうち少なくとも一方)で混合潤滑に占める境界潤滑の割合が所定割合以上となったことを推定することを含む。
このように、本実施形態に係る旋動式破砕機100によれば、流体潤滑軸受である下部軸受15と境界潤滑軸受である主軸スラスト軸受2との潤滑状態を、1つのシステムで個別に推定し、これにより、どこに焼付き予兆が発生しているのかを推定することができる。同様に、本実施形態に係る潤滑状態推定方法によれば、一連の処理で、流体潤滑軸受と境界潤滑軸受との潤滑状態を個別に推定し、これにより、どこに焼付き予兆が発生しているのかを推定することができる。つまり、流体潤滑軸受と境界潤滑軸受とについて、夫々に潤滑状態を推定する計測を個別に行う必要がない。これにより、流体潤滑軸受と境界潤滑軸受の双方の軸受の潤滑状態の推定のために旋動式破砕機100が備える機器の点数を削減することができる。そのうえ、焼付き予兆が発生している箇所を推定できるので、旋動式破砕機100の運転を止めて分解しなくても、交換すべき部品を特定することができる。
本開示の前述の議論は、例示及び説明の目的で提示されたものであり、本開示を本明細書に開示される形態に限定することを意図するものではない。例えば、前述の詳細な説明では、本開示の様々な特徴は、本開示を合理化する目的で複数の実施形態にまとめられている。但し、本開示に含まれる複数の特徴は、上記で論じたもの以外の代替の実施形態、構成、又は態様に組み合わせることができる。
本明細書で開示する潤滑状態推定装置53の機能は、開示された機能を実行するように構成又はプログラムされた汎用プロセッサ、専用プロセッサ、集積回路、ASIC(Application Specific Integrated Circuits)、従来の回路、及び/又は、それらの組み合わせを含む回路、又は、処理回路を使用して実行できる。プロセッサは、トランジスタやその他の回路を含むため、処理回路又は回路と見做される。本開示において、回路、ユニット、又は手段は、列挙された機能を実行するハードウェアである。ハードウェアは、本明細書に開示されているハードウェアであってもよいし、或いは、列挙された機能を実行するようにプログラム又は構成されているその他の既知のハードウェアであってもよい。ハードウェアが回路の一種と考えられるプロセッサである場合、回路、手段、またはユニットは、ハードウェアとソフトウェアの組み合わせであり、ソフトウェアはハードウェア及び/又はプロセッサの構成に使用される。
本開示の旋動式破砕機100において、潤滑状態推定システム50,50A,50Bの構成要素である潤滑状態推定装置53と各種の指標測定器は同じ場所に設けられてなくてもよい。例えば、各種の指標測定器が旋動式破砕機100に付帯して設けられ、潤滑状態推定装置53の機能の少なくとも一部分が旋動式破砕機100から遠隔地に設けられていてもよい。この場合、各種の指標検出器で検出された指標の値が通信ネットワークを通じて潤滑状態推定装置53へ伝達され、潤滑状態推定装置53は算出した潤滑状態の推定結果を通信ネットワークを通じて旋動式破砕機100の制御装置等へしてもよい。また、例えば、潤滑状態推定装置53の機能の少なくとも一部分がクラウドサービスにより提供されてもよい。この場合、コンピュータからアクセスを受けたクラウドサーバが所定のプログラムを実行することによって潤滑状態推定装置53として機能し、コンピュータへ故障予兆診断結果を返してもよい。潤滑状態推定装置53は潤滑状態の推定結果をクラウドストレージに保存してもよい。
2 :主軸スラスト軸受
23 :スラスト滑り軸受
4 :偏心スリーブ
5 :主軸
6 :主軸昇降用油圧シリンダ
7 :ボス
8 :駆動モータ
8a :駆動軸
10 :主軸軸受
11 :スリーブ軸受
12 :マントルコア
13 :マントル
14 :コンケーブ
15 :下部軸受
16 :破砕室
17 :上部軸受
18 :スパイダ
19 :ベベルギア
20 :動力伝達機構
22 :プーリ
24 :仕切板
27 :油圧室
31 :上部フレーム
32 :下部フレーム
41 :回転軸
42 :ジャーナル滑り軸受
43 :潤滑膜
44 :回転ディスク
45 :スラスト軸受
46 :潤滑膜
50,50A,50B :潤滑状態推定システム
51,51a~f :指標測定器
53 :潤滑状態推定装置
55 :シリンダ圧力測定器
56 :軸動力測定器
60 :滑り軸受装置
61 :回転軸
62 :軸受部材
63 :潤滑膜
65 :機械装置
66,67 :摺動部材
68 :潤滑膜
100 :旋動式破砕機
Claims (21)
- 相対運動をする2つの物体の摺動面の潤滑状態を推定する潤滑状態推定装置であって、
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、
S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記プロセッサが、前記第1指標及び前記第2指標を取得し、前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定する、
潤滑状態推定装置。 - 前記プロセッサは、前記摺動面が流体潤滑であると推定したときに、前記第1指標の時間変化率に対する前記第2指標の時間変化率の相対比、及び、前記第2指標が周期的に変化する場合における前記第1指標の振幅に対する前記第2指標の振幅の相対比の少なくとも一方に基づいて、前記摺動面の流体潤滑の健全性を評価する、
請求項1に記載の潤滑状態推定装置。 - 前記プロセッサは、前記摺動面が混合潤滑であると推定したときに、前記第1指標の時間変化率に対する前記第2指標の時間変化率の相対比、及び、前記第2指標が周期的に変化する場合における前記第1指標の振幅に対する前記第2指標の振幅の相対比の少なくとも一方に基づいて、前記摺動面の混合潤滑に占める境界潤滑の割合を推定する、
請求項1又は2に記載の潤滑状態推定装置。 - コンケーブと、
前記コンケーブの内部に配置された主軸と、
前記主軸に設けられたマントルと、
前記主軸の下部が回転自在に挿入された偏心スリーブと、
前記偏心スリーブが回転自在に挿入されたボスと、
前記偏心スリーブを回転駆動する駆動軸と、
前記駆動軸を回転駆動する駆動モータと、
前記主軸を昇降可能に支持する油圧シリンダと、
前記主軸と前記偏心スリーブとの間に形成されたジャーナル滑り軸受、前記偏心スリーブと前記ボスとの間に形成されたジャーナル滑り軸受、及び、前記主軸と前記油圧シリンダとの間に形成されたスラスト滑り軸受のうち少なくとも一つの滑り軸受と、
前記第1指標を測定する少なくとも1つの第1指標測定器と、
前記第2指標を測定する少なくとも1つの第2指標測定器と、
前記滑り軸受において摺動面の潤滑状態を推定する請求項1~3のいずれか一項に記載の潤滑状態推定装置とを、備える、
旋動式破砕機。 - 前記第1指標測定器が、前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標と前記駆動軸の軸動力又は当該軸動力と相関する指標とを測定する測定器を含み、前記第2指標測定器が、前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標を測定する測定器を含み、
前記第1指標が{前記軸動力又は当該軸動力と相関する指標/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数であり、前記第2指標が前記シリンダ圧力又は当該シリンダ圧力と相関する指標に相関する関数である、
請求項4記載の旋動式破砕機。 - 潤滑膜を介して回転体を支持する軸受部材と、
前記第1指標を測定する少なくとも1つの第1指標測定器と、
前記第2指標を測定する少なくとも1つの第2指標測定器と、
前記回転体と前記軸受部材の摺動面の潤滑状態を推定する請求項1~3のいずれか一項に記載の潤滑状態推定装置とを、備える、
滑り軸受装置。 - 潤滑膜を介して接触しながら相対運動する一組の摺動部材と、
前記第1指標を測定する少なくとも1つの第1指標測定器と、
前記第2指標を測定する少なくとも1つの第2指標測定器と、
前記一組の摺動部材の摺動面の潤滑状態を推定する請求項1~3のいずれか一項に記載の潤滑状態推定装置とを、備える、
機械装置。 - 相対運動をする2つの物体の摺動面の潤滑状態を推定する潤滑状態推定方法であって、
前記摺動面の摩擦係数又は当該摩擦係数と相関する指標を第1指標とし、
S*=μv/F(但し、μは前記摺動面に介在する潤滑剤の粘度、vは前記摺動面の摺動速度、Fは前記摺動面の押付荷重)で示される物理量S*又は当該物理量S*と相関する指標を第2指標とし、
前記第1指標及び前記第2指標を取得すること、及び、
前記第1指標の時間変化率の正負と前記第2指標の時間変化率の正負との相関に基づいて、前記摺動面の潤滑状態を推定することを含む、
潤滑状態推定方法。 - 前記摺動面が流体潤滑と推定されたときに、前記第1指標の時間変化率に対する前記第2指標の時間変化率の相対比、及び、前記第2指標が周期的に変化する場合における前記第1指標の振幅に対する前記第2指標の振幅の相対比の少なくとも一方に基づいて、前記摺動面の流体潤滑の健全性を評価することを、更に含む、
請求項8に記載の潤滑状態推定方法。 - 前記摺動面が混合潤滑と推定されたときに、前記第1指標の時間変化率に対する前記第2指標の時間変化率の相対比、及び、前記第2指標が周期的に変化する場合における前記第1指標の振幅に対する前記第2指標の振幅の相対比の少なくとも一方に基づいて、前記摺動面の混合潤滑に占める境界潤滑の割合を推定することを、更に含む、
請求項8又は9に記載の潤滑状態推定方法。 - 回転軸と軸受との摺動面の潤滑状態を推定する潤滑状態推定装置であって、
少なくとも1つのプロセッサと、
前記プロセッサによって実行されるプログラムが記憶された少なくとも一つのメモリとを備え、
前記回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標とし、
前記摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標とし、
前記プロセッサは、前記第3指標及び前記第4指標を取得し、縦軸が前記第3指標を表し横軸が前記第4指標を表す図表に取得した前記第3指標及び前記第4指標をプロットすることを少なくとも2回以上繰り返し、前記図表に表れる線の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて、前記摺動面の潤滑状態を推定する、
潤滑状態推定装置。 - コンケーブと、
前記コンケーブの内部に配置された主軸と、
前記主軸に設けられたマントルと、
前記主軸の下部が回転自在に挿入された偏心スリーブと、
前記偏心スリーブが回転自在に挿入されたボスと、
前記偏心スリーブを回転駆動する駆動軸と、
前記駆動軸を回転駆動する駆動モータと、
前記主軸を昇降可能に支持する油圧シリンダと、
前記主軸と前記偏心スリーブとの間に形成されたジャーナル滑り軸受、前記偏心スリーブと前記ボスとの間に形成されたジャーナル滑り軸受、及び、前記主軸と前記油圧シリンダとの間に形成されたスラスト滑り軸受のうち少なくとも一つの滑り軸受と、
前記第3指標を測定する少なくとも1つの第3指標測定器と、
前記第4指標を測定する少なくとも1つの第4指標測定器と、
前記滑り軸受において摺動面の潤滑状態を推定する請求項11に記載の潤滑状態推定装置とを、備える、
旋動式破砕機。 - 潤滑膜を介して回転体を支持する軸受部材と、
前記第3指標を測定する少なくとも1つの第3指標測定器と、
前記第4指標を測定する少なくとも1つの第4指標測定器と、
前記回転体と前記軸受部材の摺動面の潤滑状態を推定する請求項11に記載の潤滑状態推定装置とを、備える、
滑り軸受装置。 - 潤滑膜を介して接触しながら相対運動する一組の摺動部材と、
前記第3指標を測定する少なくとも1つの第3指標測定器と、
前記第4指標を測定する少なくとも1つの第4指標測定器と、
前記一組の摺動部材の摺動面の潤滑状態を推定する請求項11に記載の潤滑状態推定装置とを、備える、
機械装置。 - 回転軸と軸受との摺動面の潤滑状態を推定する潤滑状態推定方法であって、
前記回転軸の軸トルク又は当該軸トルクと相関する指標を第3指標とし、
前記摺動面の押付荷重又は当該押付荷重と相関する指標を第4指標とし、
前記第3指標及び前記第4指標を取得すること、及び、
縦軸が前記第3指標を表し横軸が前記第4指標を表す図表に取得した前記第3指標及び前記第4指標をプロットすることを少なくとも2回以上繰り返し、前記図表に表れる線の接線の傾き及び接線の切片を取得し、当該接線の傾き及び接線の切片の組み合わせに基づいて前記摺動面の潤滑状態を推定することを含む、
潤滑状態推定方法。 - コンケーブと、
前記コンケーブの内部に配置された主軸と、
前記主軸に設けられたマントルと、
前記主軸の下部が回転自在に挿入された偏心スリーブと、
前記偏心スリーブが回転自在に挿入されたボスと、
前記偏心スリーブを回転駆動する駆動軸と、
前記駆動軸を回転駆動する駆動モータと、
前記主軸を昇降可能に支持する油圧シリンダと、
前記主軸と前記偏心スリーブとの間に形成された第1流体潤滑軸受と、
前記偏心スリーブと前記ボスとの間に形成された第2流体潤滑軸受と、
前記主軸と前記油圧シリンダとの間に形成された境界潤滑軸受と、
{前記駆動軸の軸動力又は当該軸動力と相関する指標/前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第5指標とし、前記第5指標を測定する少なくとも1つの第5指標測定器と、
{1/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第6指標とし、前記第6指標を測定する少なくとも1つの第6指標測定器と、
前記第6指標に対する前記第5指標の変化率に基づいて前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定する潤滑状態推定装置とを備える、
旋動式破砕機。 - 前記潤滑状態推定装置は、前記変化率が0より小さい所定の第1閾値以下であるときに、前記境界潤滑軸受でスカッフィング現象が生じていることを推定する、
請求項16に記載の旋動式破砕機。 - 前記潤滑状態推定装置は、前記変化率が、前記変化率が0より小さい所定の第1閾値より大きく、且つ、0より小さい所定の第2閾値以下であるときに、前記第1流体潤滑軸受及び前記第2流体潤滑軸受のうち少なくとも1つで混合潤滑に占める境界潤滑の割合が所定割合以上となったことを推定する、
請求項16に記載の旋動式破砕機。 - コンケーブと、前記コンケーブの内部に配置された主軸と、前記主軸に設けられたマントルと、前記主軸の下部が回転自在に挿入された偏心スリーブと、前記偏心スリーブが回転自在に挿入されたボスと、前記偏心スリーブを回転駆動する駆動軸と、前記駆動軸を回転駆動する駆動モータと、前記主軸を昇降可能に支持する油圧シリンダと、前記主軸と前記偏心スリーブとの間に形成された第1流体潤滑軸受と、前記偏心スリーブと前記ボスとの間に形成された第2流体潤滑軸受と、前記主軸と前記油圧シリンダとの間に形成された境界潤滑軸受とを備える旋動式破砕機において、前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定する潤滑状態推定方法であって、
{前記駆動軸の軸動力又は当該軸動力と相関する指標/前記油圧シリンダのシリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第5指標とし、
{1/前記シリンダ圧力又は当該シリンダ圧力と相関する指標}に相関する関数を第6指標とし、
前記第5指標及び前記第6指標を取得すること、及び、
前記第6指標に対する前記第5指標の変化率に基づいて前記第1流体潤滑軸受、前記第2流体潤滑軸受及び前記境界潤滑軸受の潤滑状態を推定することを含む、
潤滑状態推定方法。 - 前記潤滑状態を推定することが、前記変化率が0より小さい所定の第1閾値以下であるときに、前記境界潤滑軸受でスカッフィング現象が生じていることを推定することを含む、
請求項19に記載の潤滑状態推定方法。 - 前記潤滑状態を推定することが、前記変化率が0より小さい所定の第1閾値より大きく、且つ、0より小さい所定の第2閾値以下であるときに、前記第1流体潤滑軸受及び前記第2流体潤滑軸受のうち少なくとも1つで混合潤滑に占める境界潤滑の割合が所定割合以上となったことを推定することを含む、
請求項19に記載の潤滑状態推定方法。
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2022538030A JP7506748B2 (ja) | 2020-07-20 | 2021-07-20 | 潤滑状態推定装置及び方法、滑り軸受装置、機械装置、並びに旋動式破砕機 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2020-123711 | 2020-07-20 | ||
| JP2020123711 | 2020-07-20 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022019315A1 true WO2022019315A1 (ja) | 2022-01-27 |
Family
ID=79729187
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2021/027231 Ceased WO2022019315A1 (ja) | 2020-07-20 | 2021-07-20 | 潤滑状態推定装置及び方法、滑り軸受装置、機械装置、並びに旋動式破砕機 |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP7506748B2 (ja) |
| WO (1) | WO2022019315A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120521674A (zh) * | 2025-07-23 | 2025-08-22 | 上海中远海运重工有限公司 | 一种结合主机工作状态的轴系负荷波动幅度识别方法 |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5395663A (en) * | 1977-02-01 | 1978-08-22 | Yaskawa Denki Seisakusho Kk | Detecting apparatus for abnormal state of bearings |
| JP2004519325A (ja) * | 2001-03-23 | 2004-07-02 | メッツオ ミネラルズ (タンペレ) オサケイシテヨ | 破砕機の軸受状態を監視する方法及びその破砕機 |
| WO2019045042A1 (ja) * | 2017-08-31 | 2019-03-07 | 株式会社アーステクニカ | 旋動式破砕機 |
| JP2019202245A (ja) * | 2018-05-21 | 2019-11-28 | 株式会社アーステクニカ | 旋動式破砕機及びその制御方法 |
Family Cites Families (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP4355872B2 (ja) * | 1999-12-09 | 2009-11-04 | 株式会社Ihi | 潤滑油の性能監視方法 |
| EP3821240B1 (en) * | 2018-07-11 | 2023-10-11 | Wärtsilä Finland Oy | System and method for determining remaining life of engine oil in an engine |
-
2021
- 2021-07-20 JP JP2022538030A patent/JP7506748B2/ja active Active
- 2021-07-20 WO PCT/JP2021/027231 patent/WO2022019315A1/ja not_active Ceased
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5395663A (en) * | 1977-02-01 | 1978-08-22 | Yaskawa Denki Seisakusho Kk | Detecting apparatus for abnormal state of bearings |
| JP2004519325A (ja) * | 2001-03-23 | 2004-07-02 | メッツオ ミネラルズ (タンペレ) オサケイシテヨ | 破砕機の軸受状態を監視する方法及びその破砕機 |
| WO2019045042A1 (ja) * | 2017-08-31 | 2019-03-07 | 株式会社アーステクニカ | 旋動式破砕機 |
| JP2019202245A (ja) * | 2018-05-21 | 2019-11-28 | 株式会社アーステクニカ | 旋動式破砕機及びその制御方法 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN120521674A (zh) * | 2025-07-23 | 2025-08-22 | 上海中远海运重工有限公司 | 一种结合主机工作状态的轴系负荷波动幅度识别方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2022019315A1 (ja) | 2022-01-27 |
| JP7506748B2 (ja) | 2024-06-26 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| Kundu et al. | A correlation coefficient based vibration indicator for detecting natural pitting progression in spur gears | |
| Kattelus et al. | Detection of gear pitting failure progression with on-line particle monitoring | |
| Towsyfyan et al. | Modelling acoustic emissions generated by tribological behaviour of mechanical seals for condition monitoring and fault detection | |
| US7559240B2 (en) | Method and device for assessing residual service life of rolling bearing | |
| Nithin et al. | A review on combustion and vibration condition monitoring of IC engine | |
| JP5990729B1 (ja) | 汎用劣化曲線作成方法及び機械寿命予測方法、並びに汎用劣化曲線作成プログラム及び機械寿命予測プログラム | |
| Baron et al. | The parameter correlation of acoustic emission and high-frequency vibrations in the assessment process of the operating state of the technical system | |
| CN101226103A (zh) | 测试弹性箔片径向轴承起飞转速的装置 | |
| US12602036B2 (en) | System for predictive operational analysis of a machinery component | |
| CN104833510A (zh) | 加速度四个阶段频率轴承故障诊断法 | |
| CN201251536Y (zh) | 一种机床主轴轴颈轴瓦摩擦磨损性能试验装置 | |
| Baron et al. | Verification of the operating condition of stationary industrial gearbox through analysis of dynamic signal, measured on the pinion bearing housing | |
| Chmelar et al. | Experimental study of lubrication film monitoring in a roller bearing by utilization of surface acoustic waves | |
| Decker et al. | Detection of particle contamination and lubrication outage in journal bearings in wind turbine gearboxes using surface acoustic wave measurements and machine learning | |
| JP7506748B2 (ja) | 潤滑状態推定装置及び方法、滑り軸受装置、機械装置、並びに旋動式破砕機 | |
| Jangra et al. | A comparative study of wear debris and vibration-based gear damage detection methods applied to mild wear in a spur gear system | |
| JP4767148B2 (ja) | 正常データベースを用いた転がり軸受の余寿命診断方法、余寿命診断システム及び余寿命診断に用いるコンピュータプログラム | |
| Zhang et al. | Interaction between gear surface wear and contact fatigue | |
| Decker et al. | Approach towards the condition monitoring of journal bearings using surface acoustic wave technology | |
| Gosar et al. | On the importance of the experimental setup design in hydrodynamic journal bearing friction measurement | |
| Sinha et al. | Diagnosis and prognosis of oil whirl in journal bearing using acoustical measurement | |
| Neugebauer et al. | Condition-based preventive maintenance of main spindles | |
| Šaravanja et al. | APPLICATION OF VIBRATION ANALYSIS IN JOURNAL BEARING PROBLEMS DIAGNOSTICS. | |
| Baron et al. | The dynamic parameters correlation assessment of the textile machine high-speed bearings in changed technological conditions | |
| EP4074982A1 (en) | Closed loop control employing magnetostrictive sensing |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21845798 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2022538030 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 21845798 Country of ref document: EP Kind code of ref document: A1 |