WO2020195321A1 - 作業工具およびこれを備えた制御システム - Google Patents
作業工具およびこれを備えた制御システム Download PDFInfo
- Publication number
- WO2020195321A1 WO2020195321A1 PCT/JP2020/006021 JP2020006021W WO2020195321A1 WO 2020195321 A1 WO2020195321 A1 WO 2020195321A1 JP 2020006021 W JP2020006021 W JP 2020006021W WO 2020195321 A1 WO2020195321 A1 WO 2020195321A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- output
- motor
- power efficiency
- unit
- work tool
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23D—PLANING; SLOTTING; SHEARING; BROACHING; SAWING; FILING; SCRAPING; LIKE OPERATIONS FOR WORKING METAL BY REMOVING MATERIAL, NOT OTHERWISE PROVIDED FOR
- B23D49/00—Machines or devices for sawing with straight reciprocating saw blades, e.g. hacksaws
- B23D49/10—Hand-held or hand-operated sawing devices with straight saw blades
- B23D49/16—Hand-held or hand-operated sawing devices with straight saw blades actuated by electric or magnetic power or prime movers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25B—TOOLS OR BENCH DEVICES NOT OTHERWISE PROVIDED FOR, FOR FASTENING, CONNECTING, DISENGAGING, OR HOLDING
- B25B21/00—Portable power-driven screw or nut setting or loosening tools; Attachments for drilling apparatus serving the same purpose
- B25B21/02—Portable power-driven screw or nut setting or loosening tools; Attachments for drilling apparatus serving the same purpose with means for imparting impact to screwdriver blade or nut socket
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25F—COMBINATION OR MULTI-PURPOSE TOOLS NOT OTHERWISE PROVIDED FOR; DETAILS OR COMPONENTS OF PORTABLE POWER-DRIVEN TOOLS NOT PARTICULARLY RELATED TO THE OPERATIONS PERFORMED AND NOT OTHERWISE PROVIDED FOR
- B25F5/00—Details or components of portable power-driven tools not particularly related to the operations performed and not otherwise provided for
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B27—WORKING OR PRESERVING WOOD OR SIMILAR MATERIAL; NAILING OR STAPLING MACHINES IN GENERAL
- B27B—SAWS FOR WOOD OR SIMILAR MATERIAL; COMPONENTS OR ACCESSORIES THEREFOR
- B27B17/00—Chain saws; Equipment therefor
- B27B17/08—Drives or gearings; Devices for swivelling or tilting the chain saw
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B27—WORKING OR PRESERVING WOOD OR SIMILAR MATERIAL; NAILING OR STAPLING MACHINES IN GENERAL
- B27B—SAWS FOR WOOD OR SIMILAR MATERIAL; COMPONENTS OR ACCESSORIES THEREFOR
- B27B19/00—Other reciprocating saws with power drive; Fret-saws
- B27B19/02—Saws with a power- driven blade chucked at both ends or at one end only, e.g. jig saws, scroll saws
- B27B19/04—Saws with a power- driven blade chucked at both ends or at one end only, e.g. jig saws, scroll saws characterised by power drive, e.g. by electromagnetic drive
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B27—WORKING OR PRESERVING WOOD OR SIMILAR MATERIAL; NAILING OR STAPLING MACHINES IN GENERAL
- B27B—SAWS FOR WOOD OR SIMILAR MATERIAL; COMPONENTS OR ACCESSORIES THEREFOR
- B27B19/00—Other reciprocating saws with power drive; Fret-saws
- B27B19/02—Saws with a power- driven blade chucked at both ends or at one end only, e.g. jig saws, scroll saws
- B27B19/09—Saws with a power- driven blade chucked at both ends or at one end only, e.g. jig saws, scroll saws portable
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P29/00—Arrangements for regulating or controlling electric motors, appropriate for both AC and DC motors
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P6/00—Arrangements for controlling synchronous motors or other dynamo-electric motors using electronic commutation dependent on the rotor position; Electronic commutators therefor
Definitions
- the present invention relates to, for example, a work tool provided with a motor such as an electric screwdriver, a jigsaw, and a chainsaw, and a control system provided with the motor.
- a motor such as an electric screwdriver, a jigsaw, and a chainsaw
- a control system provided with the motor.
- the "maximum torque” reminds the user of the work efficiency
- the "work amount” reminds the user of the battery life (the time until the battery runs out and is replaced with a new battery).
- the battery life corresponds to the "power efficiency”.
- An object of the present invention is to provide a work tool capable of providing an optimum work tool for the user and a control system provided with the work tool.
- the work tool according to the first invention includes a motor, a trigger switch, a machine output measuring unit, and a power efficiency measuring unit.
- the trigger switch is operated by the user and adjusts the output of the motor according to the amount of operation.
- the mechanical output measuring unit measures the mechanical output with respect to the load torque of the motor that rotates by operating the trigger switch.
- the power efficiency measuring unit measures the power efficiency with respect to the load torque of the motor that rotates by operating the trigger switch.
- the work tool includes various tools driven by a motor such as an electric screwdriver, a jigsaw, and a chainsaw.
- the mechanical output is the mechanical output with respect to the load torque of the motor, and is calculated by multiplying the rotation speed of the motor by the torque.
- Power efficiency is the power efficiency with respect to the load torque of the motor, which is the amount of power consumed per unit time by the motor, that is, in the case of a battery-powered motor, the battery lasts (the battery runs out and a new battery is used. Time to replace).
- the machine output and the power efficiency with respect to the load torque of the motor are measured separately, and the machine output and the power efficiency are mainly displayed or output to an external device or the like. It is a feature.
- the machine output and the power efficiency can be separately displayed and output to the user or the manager of the work tool as the performance of the work tool.
- the user or the manager can provide the optimum work tool for the user by recognizing the performance of the work tool and using it as it is or making necessary adjustments. ..
- the work tool according to the second invention is the work tool according to the first invention, and displays the machine output measured by the machine output measuring unit and the power efficiency measured by the power efficiency measuring unit, respectively. It also has a display unit.
- the measured machine output and power efficiency are displayed on a display unit provided on the work tool.
- the user can confirm the machine output and power efficiency displayed on the display unit, accurately recognize the performance of the work tool, and consider the balance between the machine output and power efficiency.
- the constraints of the motor can be set so as to achieve the optimum balance.
- the user can accurately recognize and use the mechanical output and power efficiency of the work tool, and at the same time, obtain the desired performance in which the motor is driven by the constraints set according to the user's request. It is possible to provide a work tool that has been carried.
- the work tool according to the third invention is the work tool according to the first or second invention, and the machine output measured by the machine output measuring unit and the power efficiency measured by the power efficiency measuring unit are measured. It also has an output unit that outputs to the outside.
- the measured machine output and power efficiency are output to, for example, an external device such as a PC (Personal Computer), a smartphone, or a tablet terminal.
- the user can confirm the machine output and power efficiency displayed on the display screen of an external device such as a PC, accurately recognize the performance of the work tool, and can accurately recognize the machine output and power efficiency. It is possible to set the constraint conditions of the motor so as to obtain the optimum balance while considering the balance with. As a result, the user can accurately recognize and use the mechanical output and power efficiency of the work tool, and at the same time, obtain the desired performance in which the motor is driven by the constraints set according to the user's request. It is possible to provide a work tool that has been carried.
- the work tool according to the fourth invention is a work tool according to any one of the first to third inventions, and the machine output measuring unit calculates a load torque of the motor from the motor current flowing through the motor. It has a torque calculation unit and a first calculation unit that calculates a first machine output based on the load torque calculated by the load torque calculation unit and the rotation speed of the motor.
- the load torque of the motor is calculated from the motor current flowing through the motor when the trigger switch is operated, and the machine output (first) is based on the calculated load torque and the rotation speed of the motor.
- Machine output is calculated.
- the load torque can be calculated from the motor current detected by actually operating the trigger switch, and the measured value of the machine output can be calculated based on the load torque and the rotation speed of the motor.
- the work tool according to the fifth invention is the work tool according to the fourth invention, and the machine output measuring unit serves as a reference for the first machine output calculated by the first calculation unit and the machine output of the motor. It further has a first correction unit that compares the reference machine output and corrects the first machine output based on the difference between the first machine output and the reference machine output.
- the first machine output calculated by the first calculation unit is compared with the reference value (reference machine output) of the machine output of the motor, and the first machine output is corrected based on the difference.
- the reference mechanical output which is the reference of the mechanical output of the motor
- the reference mechanical output is a reference value determined by the characteristics of the motor mounted on the work tool, and may be stored in advance in the storage unit of the work tool, for example. It may be received from the outside by communication. Thereby, by correcting the measured value of the machine output, for example, the accuracy of the machine output displayed or output to an external device or the like can be improved.
- the work tool according to the sixth invention is a work tool according to any one of the first to fifth inventions, and the power efficiency measuring unit has an input power input to the motor and an output output from the motor. It has a second calculation unit that calculates the first power efficiency based on the electric power and the load torque of the motor.
- the power efficiency (first power efficiency) is calculated based on the input power input to the motor, the output power output from the motor, and the load torque of the motor.
- the measured value of the power efficiency can be calculated based on the input power and the output power detected by actually operating the trigger switch and the load torque of the motor.
- the work tool according to the seventh invention is the work tool according to the sixth invention, and the power efficiency measuring unit serves as a reference for the first power efficiency calculated by the second calculation unit and the power efficiency of the motor. It further has a second correction unit that compares the reference power efficiency and corrects the first power efficiency based on the difference between the first power efficiency and the reference power efficiency.
- the first power efficiency calculated by the second calculation unit is compared with the reference value (reference power efficiency) of the power efficiency of the motor, and the first power efficiency is corrected based on the difference.
- the reference power efficiency which is a reference of the power efficiency of the motor, is a reference value determined by the characteristics of the motor mounted on the work tool, and may be stored in advance in the storage unit of the work tool, for example. , May be received from the outside by communication. Thereby, by correcting the measured power efficiency value, for example, the accuracy of the power efficiency displayed or output to an external device or the like can be improved.
- the work tool according to the eighth invention is the work tool according to any one of the first to seventh inventions, and further includes an output increase control unit for increasing the output of the motor.
- output increase control such as PWM (Pulse Width Modulation) control is performed.
- PWM Pulse Width Modulation
- the work tool according to the ninth invention is the work tool according to the eighth invention, and the output increase control unit implements at least one of PWM control, advance angle control, and 150-degree energization method control.
- the motor output increase control described above at least one of PWM control, advance angle control, and 150-degree energization method control is performed. Thereby, these motor controls can be selected or combined to increase the output of the motor.
- the work tool according to the tenth invention is a work tool according to any one of the first to ninth inventions, and further includes a machine output increasing mechanism for increasing the machine output.
- a machine output increasing mechanism for increasing the machine output As a means for increasing the output of the motor, a mechanical output increasing mechanism capable of mechanically increasing the mechanical output is provided. As a result, by increasing the output of the motor from the mechanical aspect, the work tool can have the performance (mechanical output) required by the user.
- the work tool according to the eleventh invention is the work tool according to the tenth invention, and the machine output increasing mechanism is an orbital or an impact hammer.
- the mechanical output of the work tool is increased by an orbital used as a mechanical output increasing mechanism of a work tool such as a jigsaw, or an impact hammer used as a mechanical output increasing mechanism of a work tool such as an electric screwdriver.
- the mechanical output of various work tools can be increased from the mechanical aspect.
- the work tool according to the twelfth invention is a work tool according to any one of the first to eleventh inventions, and feedback control is performed under constraints set based on machine output and power efficiency. It is further provided with a feedback control unit for performing the above.
- the user changes the machine output and power efficiency that are displayed or output to an external device, and the constraint conditions set in the external terminal such as a PC are set based on the changed machine output and power efficiency. It is possible to receive and perform feedback control of the motor under the constraint condition. As a result, it is possible to provide a work tool having mechanical output and power efficiency according to the user's request.
- the work tool according to the thirteenth invention is a work tool according to any one of the first to twelfth inventions, and further includes a sensor for detecting a value related to motor control. As a result, various data related to motor control can be acquired using various sensors.
- the work tool according to the fourteenth invention is the work tool according to the thirteenth invention, and the sensor flows through the sensor for detecting the operation amount of the trigger switch, the voltage sensor for detecting the voltage applied to the motor, and the motor. It includes a current sensor that detects current and a temperature sensor that detects the temperature of the motor. As a result, the detection results of the sensor that detects the operation amount of the trigger switch, the voltage sensor of the motor, the current sensor, the temperature sensor, and the like can be acquired. As a result, it is possible to provide a work tool that is more convenient for the user by, for example, performing feedback control of the work tool using these data.
- the work tool according to the fifteenth invention is a work tool according to any one of the first to fourteenth inventions, and the motor is a brushless motor.
- the motor is a brushless motor.
- the control system displays a work tool according to any one of the first to fifteenth inventions, a storage unit for storing machine output and power efficiency, and information based on machine output and power efficiency. It includes an external terminal having a display unit.
- the external terminal includes a PC (Personal Computer), a tablet terminal, a smartphone, etc. used by a user or an administrator.
- the machine output and power efficiency data output from the work tool are saved in the storage unit on the external terminal side, and the saved data is displayed on the display unit, so that, for example, the user or the administrator can use the data.
- More appropriate constraint conditions and the like can be set while looking at the data and graphs showing the machine output and power efficiency displayed on the display unit of the external terminal. As a result, it is possible to provide a work tool that is easy for the user to use.
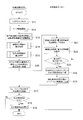
- FIG. 5 is a flowchart showing a flow of control executed by the work tool of FIG. 1 and an external terminal.
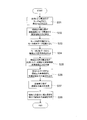
- the flowchart which shows the flow of the estimation process of the machine output curve carried out by the work tool of FIG.
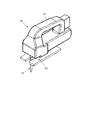
- FIG. 3 is a perspective view showing a configuration of a jigsaw as an example of the work tool of FIG.
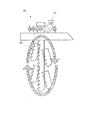
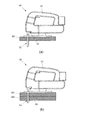
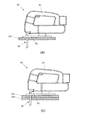
- FIG. 5 is a diagram schematically showing the movement of a saw blade when the output is increased by using an orbital in the jigsaw of FIG. (A) and (b) are views showing a state of cutting metal plates having different thicknesses using the jigsaw of FIG. (A) and (b) are views showing a state of cutting wooden boards having different thicknesses using the jigsaw of FIG.
- the block diagram of the structure of the work tool which concerns on another embodiment of this invention.
- FIG. 1 is a block diagram showing a configuration of the control system 100 of the present embodiment.
- the control system 100 of the present embodiment includes a work tool 10 and an external terminal 20.
- the work tool 10 is a tool driven by a motor 111 such as a jigsaw, a chainsaw, or an electric screwdriver.
- the external terminal 20 displays, for example, log data of control values related to the drive of the motor 111 mounted on the work tool 10, machine output of the work tool 10, power efficiency, and the like, and constraints for subsequent control are set. To.
- the mechanical output is, for example, the mechanical output of the work tool 10 with respect to the load torque of the motor 111, and is calculated by multiplying the rotation speed of the motor 111 by the torque.
- the power efficiency is, for example, the power efficiency of the work tool 10 with respect to the load torque of the motor 111, and means the power consumption per unit time by the motor 111. Therefore, in the case of the battery-powered motor 111 in which power is supplied from the replaceable battery 151 as in the present embodiment, the battery 151 lasts until the battery runs out and is replaced with a new battery. Time) means.
- the work tool 10 is a kind of power consuming body on which the motor 111 is mounted, and as shown in FIG. 1, the mechanism unit 11, the input unit 12, the control unit 13, the log output unit 14, and the power supply unit 15 And a measuring unit 16.
- the mechanical unit 11 drives a tool such as a jigsaw saw blade.
- the input unit 12 transmits the values detected by various sensors provided on the work tool 10 to the control unit 13.
- the control unit 13 controls the drive of the mechanism unit 11 based on the input information from the input unit 12 and the like.
- the log output unit 14 transmits the log data of the control value at the time of driving, the machine output measured by the measurement unit 16, and the power efficiency data to the external terminal 20.
- the power supply unit 15 supplies electric power to the mechanism unit 11, the input unit 12, the control unit 13, the log output unit 14, and the measurement unit 16.
- the mechanism unit 11 includes a motor 111, a speed reducer 112, an output unit 113, a position detection unit 114, and an output increase mechanism (mechanical output increase mechanism) 115.
- the motor 111 is rotationally driven based on an instruction from the control unit 13.
- the motor 111 for example, a three-phase DC brushless motor can be used.
- the speed reducer 112 is composed of a gear mechanism or the like, and amplifies the torque of the motor 111. The rotation is synchronized between the speed reducer 112 and the motor 111, and the rotation of the motor 111 is decelerated and transmitted to the output unit 113.
- the output unit 113 is, for example, a jigsaw saw blade or the like, and converts the output of the motor 111 into mechanical work according to a purpose such as cutting.
- the rotation is synchronized between the speed reducer 112 and the output unit 113, and the rotation of the motor 111 is output.
- the position detection unit 114 is a magnetic sensor or the like represented by a Hall IC.
- the position detection unit 114 detects the rotation angle position of the motor 111 and transmits it to the control unit 13.
- the position detection unit 114 may be configured without using a sensor, and detects the rotation angle position of the motor 111 by detecting the current.
- the rotation is synchronized between the position detection unit 114 and the motor 111.
- the output increasing mechanism 115 includes, for example, an orbital mounted near the saw blade when the work tool 10 is a jigsaw, an impact hammer mounted near the tip when the work tool 10 is an electric screwdriver, and the like. Each is a mechanism that increases the mechanical output of the work tool 10.
- the input unit 12 includes a trigger switch 121 and a sensor circuit 122.
- the trigger switch 121 is an analog switch, which is provided on the handle portion of the work tool 10, and adjusts the output of the motor 111 according to the pulling amount (operation amount) thereof.
- the sensor circuit 122 transmits the input pull amount of the trigger switch 121 to the control unit 13.
- the sensor circuit 122 includes a pulling amount sensor 122a, a voltage sensor 122b, a current sensor 122c, a torque sensor 122d, and a temperature sensor 122e.
- the pull amount sensor 122a detects the pull amount (operation amount) of the trigger switch 121.
- the voltage sensor 122b detects the voltage applied to the motor 111.
- the current sensor 122c detects the current flowing through the motor 111.
- the torque sensor 122d detects the torque generated when the motor 111 rotates when, for example, the work tool 10 is used to perform bolting work on a predetermined material.
- the temperature sensor 122e detects the temperature of the motor 111 and the like.
- the sensor circuit 122 may include a sensor other than these sensors, for example, a sensor (humidity sensor) for measuring the ambient environment.
- Control unit 13 As shown in FIG. 1, the control unit 13 controls the drive of the mechanism unit 11 based on the constraint conditions set by the external terminal 20 capable of communicating with the work tool 10.
- the control unit 13 includes a feedback control unit 131, a motor drive circuit 132, a rotation speed calculation unit 133, and an output increase control unit 134.
- the feedback control unit 131 receives various sensor information input from the sensor circuit 122 and a rotation speed under the constraint condition received from the external terminal 20 according to the pull amount (operation amount) of the trigger switch 121 by the user.
- the output of the PWM (Pulse Width Modulation) signal is determined based on the rotation angle position and the rotation speed input from the calculation unit 133.
- the constraint conditions are a target value (fixed value), a vertical value limiter, a target value table, a sequence operation, and the like, which are set in the external terminal 20 described later and transmitted to the work tool 10. Then, the feedback control unit 131 transmits a PWM signal to the motor drive circuit 132.
- the PWM signal transmitted from the feedback control unit 131 is determined according to the pulling amount of the trigger switch 121 and the like, and is, for example, 90%, 50%, 10%, and the like. As a result, the output of the motor can be adjusted according to the pulling amount of the trigger switch 121 and the like.
- the motor drive circuit 132 performs a commutation operation according to the rotation angle position detected by the position detection unit 114 of the mechanism unit 11, and the motor 111 is based on the ON duty ratio by the PWM signal input from the feedback control unit 131. The average voltage applied to the UVW phase of is switched.
- the rotation speed calculation unit 133 calculates the rotation speed of the motor 111 from the output pulse interval detected by the position detection unit 114 of the mechanism unit 11. Then, the rotation speed calculation unit 133 transmits the rotation angle position input from the position detection unit 114 and the calculated rotation speed to the feedback control unit 131.
- the output increase control unit 134 controls so as to increase the output of the motor 111 from the control surface based on the output increase setting input from the feedback control unit 131. Specifically, the output increase control unit 134 increases the output of the motor 111 by transmitting an output increase control signal to the motor drive circuit 132 so as to perform advance angle control, 150-degree energization method control, and the like. ..
- the control for increasing the output of the motor 111 includes the PWM control performed by the feedback control unit 131.
- the log output unit 14 transmits data of various control amounts and the machine output and power efficiency of the work tool 10 described later to the external terminal 20.
- the various control amounts include a target value (for example, rotation speed), an output value (for example, duty ratio), and a sensor value (detection value of various sensors described above, for example, a trigger pull amount).
- the log output unit 14 contains the values of various sensors detected by the sensor circuit 122, the PWM output determined by the feedback control unit 131, the rotation position / rotation speed calculated by the rotation speed calculation unit 133, and the position detection unit 114.
- Various data such as the rotation angle position detected in the above, the machine output measured by the measuring unit 16, and the power efficiency are input.
- the power supply unit 15 supplies electric power to the mechanism unit 11, the input unit 12, the control unit 13, the log output unit 14, and the measurement unit 16.
- the power supply unit 15 has a battery 151 and a battery control unit 152.
- the battery 151 is a replaceable secondary battery, and for example, an 18 V lithium ion battery or the like is used.
- the battery control unit 152 is an electronic circuit for charging / discharging a battery 151 such as a lithium ion battery.
- the measuring unit 16 receives data such as motor voltage and motor current, battery voltage and battery current, and rotation speed of motor 111, and estimates a mechanical output curve and a power efficiency curve. More specifically, as shown in FIG. 2, the measuring unit 16 has a mechanical output curve estimation unit (mechanical output measuring unit) 161 and a power efficiency curve estimating unit (power efficiency measuring unit) 162.
- the machine output curve estimation unit 161 transmits the machine output curve estimated based on the input motor current and the rotation speed of the motor 111 to the log output unit 14.
- the machine output curve estimation unit 161 includes a load torque calculation unit 161a, a machine output calculation unit (first calculation unit) 161b, a motor characteristic storage unit 161c, and a reference curve acquisition unit 161d. It has a machine output difference calculation unit 161e and a curve estimation unit (first correction unit) 161f.
- the load torque calculation unit 161a receives the motor current transmitted from the motor drive circuit 132 according to the operation amount of the trigger switch 121, calculates the load torque of the motor 111, and transmits it to the machine output calculation unit 161b.
- the machine output calculation unit (first calculation unit) 161b is a machine actually measured as a provisional value based on the load torque received from the load torque calculation unit 161a and the rotation speed of the motor 111 input from the rotation speed calculation unit 133. Calculate the output (first machine output). Then, the machine output calculation unit 161b transmits the load torque and the actually measured machine output (first machine output) to the machine output difference calculation unit 161e.
- the motor characteristic storage unit 161c stores the characteristic data of the motor 111 mounted on the work tool 10, and transmits the motor characteristic data to the reference curve acquisition unit 161d.
- the reference curve acquisition unit 161d reads the characteristic data of the motor 111 from the motor characteristic storage unit 161c, acquires the machine output reference curve (reference machine output), and transmits the machine output reference curve to the machine output difference calculation unit 161e.
- the machine output difference calculation unit 161e compared the machine output (first machine output) as a provisional value received from the machine output calculation unit 161b with the machine output reference curve (reference machine output) received from the reference curve acquisition unit 161d. The difference is transmitted to the curve estimation unit 161f.
- the curve estimation unit (first correction unit) 161f corrects the machine output (first machine output) as a provisional value received from the machine output calculation unit 161b based on the difference received from the machine output difference calculation unit 161e. Then, a highly accurate machine output curve is estimated and transmitted to the log output unit 14.
- the work tool 10 of the present embodiment can measure the machine output curve separately from the power efficiency and output it to the external terminal 20 or the like via the log output unit 14.
- the power efficiency curve estimation unit 162 transmits the power efficiency curve estimated based on the input motor voltage / motor current, battery voltage / battery current, and load torque to the log output unit 14.
- the power efficiency curve estimation unit 162 includes an output power calculation unit 162a, an input power calculation unit 162b, a power efficiency calculation unit (second calculation unit) 162c, and a motor characteristic storage unit 162d. It has a reference curve acquisition unit 162e, a power efficiency difference calculation unit 162f, and a curve estimation unit (second correction unit) 161g.
- the output power calculation unit 162a receives the motor voltage / motor current output from the motor 111, and transmits the output power output from the motor 111 to the power efficiency calculation unit 162c.
- the input power calculation unit 162b receives the motor voltage / motor current input from the battery 151 to the motor 111, and transmits the input power input to the motor 111 to the power efficiency calculation unit 162c.
- the power efficiency calculation unit (second calculation unit) 162c includes the output power and input power received from the output power calculation unit 162a and the input power calculation unit 162b, and the load received from the load torque calculation unit 161a of the machine output curve estimation unit 161.
- the power efficiency (first power efficiency) as a provisional value of the motor 111 is calculated based on the torque. Then, the power efficiency calculation unit 162c transmits the load torque and the actually measured power efficiency (first power efficiency) to the power efficiency difference calculation unit 162f.
- the motor characteristic storage unit 162d stores the characteristic data of the motor 111 mounted on the work tool 10, and transmits the motor characteristic data to the reference curve acquisition unit 162e.
- the motor characteristic storage unit 161c on the machine output curve estimation unit 161 side and the motor characteristic storage unit 162d on the power efficiency curve estimation unit 162 side may be configured as a common storage unit.
- the reference curve acquisition unit 162e reads the characteristic data of the motor 111 from the motor characteristic storage unit 162d, acquires the power efficiency reference curve (reference power efficiency), and transmits the power efficiency reference curve to the power efficiency difference calculation unit 162f.
- the power efficiency difference calculation unit 162f compared the power efficiency (first power efficiency) as a provisional value received from the power efficiency calculation unit 162c with the power efficiency reference curve (reference power efficiency) received from the reference curve acquisition unit 162e. The difference is transmitted to the curve estimation unit 162g.
- the curve estimation unit (second correction unit) 162g corrects the power efficiency (first power efficiency) as a provisional value received from the power efficiency calculation unit 162c based on the difference received from the power efficiency difference calculation unit 162f. Then, a highly accurate power efficiency curve is estimated and transmitted to the log output unit 14. As described above, the work tool 10 of the present embodiment can measure the power efficiency curve separately from the machine output and output it to the external terminal 20 or the like via the log output unit 14.
- the external terminal 20 is a terminal used by a user or an administrator (for example, a PC (Personal Computer) capable of communicating with the work tool 10), and is based on data output from the log output unit 14 of the work tool 10. Then, the constraint condition of the work tool 10 is set. Then, the external terminal 20 receives the machine output curve and the power efficiency curve output from the above-mentioned work tool 10 and displays them on the display unit 22.
- a PC Personal Computer
- the external terminal 20 has a storage unit 21, a display unit 22, and a setting unit 23.
- the storage unit 21 receives and stores the log data transmitted from the log output unit 14 of the work tool 10, the machine output curve of the work tool 10, and the power efficiency curve.
- various means such as wired and wireless can be used.
- the communication means is not particularly limited, but is preferably performed wirelessly, and may be communication via the Internet.
- the display unit 22 displays the log data stored in the storage unit 21 or its waveform, and also displays a setting screen for setting the constraint conditions of the work tool 10. Further, the display unit 22 receives the machine output curve and the power efficiency curve separately measured and output by the work tool 10 described above, and displays the respective curves. As a result, the display unit 22 can confirm the machine output curve and the power efficiency curve and display the balance point between the machine output and the power efficiency.
- the setting unit 23 is based on the log data of various control amounts output from the log output unit 14, the change of the balance point by the user who confirmed the machine output curve and the power efficiency curve, or the setting change of the constraint condition.
- a constraint condition is set for a predetermined control value and transmitted to the feedback control unit 131 of the work tool 10.
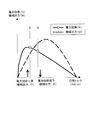
- FIG. 3 is a diagram showing an example of a mechanical output curve and a power efficiency curve with respect to the load torque displayed on the display screen of the display unit 22 included in the external terminal 20. In FIG. 3, the magnitude of the load torque at the peak position is different between the power efficiency curve shown by the solid line and the mechanical output curve shown by the broken line.
- the power efficiency at point A is higher than that at point B, but the mechanical output is smaller than that at point B.
- the power efficiency at point B is lower than at point A, but the mechanical output is higher than at point A.
- the peak with the highest power efficiency is at a position where the load torque is considerably lower than the peak of the mechanical output, so if you want to prioritize power efficiency, it is sufficient to select control at the peak position of power efficiency. There is a risk that the machine output will not be obtained.
- the peak with the highest mechanical output is located at a position where the load torque is considerably larger than the peak of power efficiency. There is a possibility that a single battery 151 will not provide sufficient working time due to a large decrease.
- the power efficiency advantage or the machine output advantage should be switched according to the setting to make the optimum setting for the user. Is preferable.
- the machine output curve and the power efficiency curve of the work tool 10 are measured in this way, and the work tool 10 is output and displayed separately to the user. It is possible to accurately grasp the performance of. Therefore, the user or the like who has confirmed the machine output curve and the power efficiency curve of the work tool 10 displayed on the display unit 22 can use the work tool 10 as it is after grasping the performance, or can achieve the desired performance. Feedback control can be performed by setting constraints.
- the work tool 10 if it is desired to enhance the performance of the work tool 10, for example, it can be mounted (tuned up) on a high-efficiency control board or motor.
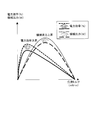
- the graph shown in FIG. 3 changes so that the peak value rises as shown in FIG.
- the power efficiency graph changes from a solid line to a short broken line, so that the peak value of the power efficiency can be increased.
- the graph of the machine efficiency changes from a long broken line to a dotted line to increase the peak value of the machine output, and the machine output is accompanied by this. Can also be raised.
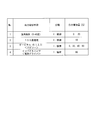
- the output increase of the work tool 10 by the output increase control unit 134 and the output increase mechanism 115 shown in FIG. 1 will be described with reference to FIG. That is, as a means for increasing the output of the work tool 10, as shown in FIG. 5, output increase control by motor control and mechanical means can be considered.
- the output increasing means table shown in FIG. 5 is, for example, preferentially selected in order from No. 1, and may be adopted in a stacking method in order from the one having the higher rank.
- advance angle control (0 to 40 degrees)
- control by a 150 degree energization method and the like can be considered. Since the advance angle control and the 150-degree energization method control are known controls, detailed description thereof will be omitted here. These advance angle control and 150 degree energization method control are performed by the output increase control unit 134 shown in FIG.
- the advance angle control is a control that maximizes the torque by matching the phase between the induced voltage of the motor and the winding current, and the amount of increase in output when the advance angle control is performed is as shown in FIG. It is about 0 to 20%.
- the 150-degree energization method control is a control by a sine wave energization method adopted as a control method for a three-phase brushless motor, and the amount of increase in output when the 150-degree energization method control is performed is as shown in FIG. It is about 10%.
- the mechanical output increasing means for example, as shown in FIG. 5, an orbital when the work tool 10 is a jigsaw, an impact hammer when the work tool 10 is an electric screwdriver, or the like can be considered.
- the output increase amount in the case of the jigsaw combined with the orbital is 0, 20, 40, 60% by the dial operation that can be selected stepwise.
- the amount of increase in output in the case of an electric screwdriver combined with an impact hammer is 80%.
- the performance required for each user is obtained.
- the above-mentioned tune-up and output increasing means in terms of control and mechanism, it is possible to increase the mechanical output and improve the power efficiency.
- the above-mentioned PWM control may be adopted as a means for increasing the mechanical output of the work tool 10 on the control surface.
- the work tool 10 of the present embodiment has the above configuration, and processes from the operation of the trigger switch 121 to the setting of the constraint condition for the control of the work tool 10 are performed according to the flowchart shown in FIG.
- steps S11 to S16 and S17 to S19 show the processing on the work tool 10 side
- steps S21 to S25 show the processing on the external terminal 20 side. That is, in step S11, the trigger switch 121 is operated by the user, and the trigger switch 121 shifts from the OFF state to the ON state. At this time, the pull amount (operation amount) of the trigger switch 121 is transmitted to the pull amount sensor 122a.
- step S12 the rotation of the motor 111 is started according to the pulling amount of the trigger switch 121 in step S11.
- the output from the pull amount sensor 122a is transmitted to the feedback control unit 131 via the log output unit 14.
- the feedback control unit 131 transmits the PWM output to the motor drive circuit 132 according to the set constraint condition and the pull amount of the trigger switch 121 output from the pull amount sensor 122a.
- the motor drive circuit 132 can control the rotation of the motor 111 according to the constraint condition and the pulling amount of the trigger switch 121.
- step S13 the rotation speed calculation unit 133 of the control unit 13 receives the signal from the position detection unit 114 of the mechanism unit 11 and starts the calculation of the rotation speed of the motor 111.
- step S14 the machine output curve estimation unit 161 of the measurement unit 16 performs a machine output curve estimation process based on the rotation speed calculated in step S13 and the motor voltage and motor current of the motor 111. To do.
- step S15 the power efficiency curve estimation unit 162 of the measurement unit 16 determines the load torque, the motor voltage and the motor current, and the battery of the power supply unit 15 calculated in the process of estimating the mechanical output curve of step S14.
- the power efficiency curve is estimated based on the battery voltage and the battery current output from 151.
- step S16 the log output unit 14 receives the machine output curve and the power efficiency curve output from the measurement unit 16 and transmits them to the external terminal 20.
- step S21 on the external terminal 20 side the machine output curve and the power efficiency curve received from the log output unit 14 of the work tool 10 are written to the storage unit 21 and stored.
- step S22 the display unit 22 reads out the machine output curve and the power efficiency curve stored in the storage unit 21 and displays them on the display screen (see FIG. 3).
- step S23 it is determined whether or not the user or the administrator has input the change of the setting condition such as the constraint condition already set in the display unit 22. Here, if there is an input, the process proceeds to step S24, and if there is no input, the process is terminated with no change.
- step S24 the setting unit 23 generates a new constraint condition from the balance point of the machine output curve and the power efficiency curve input by the user or the manager.
- step S25 the setting unit 23 transmits the new constraint condition generated in step S24 to the feedback control unit 131 on the work tool 10 side.
- step S17 on the work tool 10 side the feedback control unit 131 registers a new constraint condition received from the setting unit 23 on the external terminal 20 side.
- step S18 for example, using a display screen or the like provided on the work tool 10 side, a control surface (advance angle control, 150 degree energization method control, etc.) or a mechanical surface (orbital, impact hammer, etc.) can be used. Confirm with the user whether or not to set the output increase of the motor 111.
- the desired output increase means is selected in step S19, and the process ends.
- the output increasing control unit 134 executes the output increasing control (advance angle control, 150 degree energization method control, etc.).
- the output increasing means in terms of mechanism is selected, for example, it is controlled to display a display prompting the user to use the orbital and set the stage.
- the work tool 10 of the present embodiment performs the machine output curve estimation process performed by the measuring unit 16 in step S14 of FIG. 6 according to the flowchart of FIG.
- step S31 the load torque calculation unit 161a of the machine output curve estimation unit 161 calculates the load torque based on the input motor voltage and motor current.
- step S32 the machine output calculation unit 161b calculates the machine output (first machine output) as an actually measured value based on the input rotation speed and the calculated load torque.
- step S33 the reference curve acquisition unit 161d reads out the motor characteristic data stored in advance in the motor characteristic storage unit 161c.
- step S34 the reference curve acquisition unit 161d creates a machine output reference curve (reference machine output) based on the read motor characteristics.
- step S35 the machine output difference calculation unit 161e registers the load torque, the machine output reference curve (reference machine output), and the machine output as the measured value (first machine output).
- step S36 the machine output difference calculation unit 161e calculates the difference between the machine output reference curve (reference machine output) with respect to the load torque and the machine output (first machine output) as the measured value.
- step S37 the curve estimation unit 161f registers the difference of the machine output calculated in step S36.
- step S38 the curve estimation unit 161f multiplies the difference in machine output by the correction factor to create a machine output curve, and ends the process.
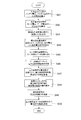
- the work tool 10 of the present embodiment performs the power efficiency curve estimation process performed in step S15 of FIG. 6 according to the flowchart of FIG.
- step 41 the input power calculation unit 162b calculates the input voltage input to the motor 111 from the input battery voltage / battery current.
- step S42 the output power calculation unit 162a calculates the output power output from the motor 111 from the input motor voltage / motor current.
- step S43 the power efficiency calculation unit 162c acquires the load torque from the load torque calculation unit 161a on the machine output curve estimation unit 161 side. At this time, the power efficiency calculation unit 162c acquires the output power and the input power from the output power calculation unit 162a and the input power calculation unit 162b, respectively.
- step S44 the power efficiency calculation unit 162c calculates the power efficiency (first power efficiency) as an actually measured value from the load torque, the input power, and the output power.
- step S45 the reference curve acquisition unit 162e reads out the motor characteristic data previously stored in the motor characteristic storage unit 162d.
- step S46 the reference curve acquisition unit 162e creates a power efficiency reference curve (reference power efficiency) based on the read motor characteristics.
- step S47 the power efficiency difference calculation unit 162f registers the load torque, the power efficiency reference curve (reference power efficiency), and the power efficiency as the measured value (first power efficiency).
- step S48 the power efficiency difference calculation unit 162f calculates the difference between the power efficiency reference curve (reference power efficiency) with respect to the load torque and the power efficiency (first power efficiency) as an actually measured value.
- step S49 the curve estimation unit 162g registers the difference in power efficiency calculated in step S48.
- step S50 the curve estimation unit 162g multiplies the difference in power efficiency by the correction factor to create a power efficiency curve, and ends the process.
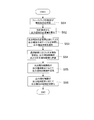
- the work tool 10 of the present embodiment has the above configuration, and is mounted on the work tool 10 based on the constraint conditions set or changed on the external terminal 20 side according to the flowchart shown in FIG. Feedback control of the motor 111 is performed.
- step 51 the feedback control unit 131 confirms the constraint condition received from the external terminal 20.
- step S52 the feedback control unit 131 calculates the required amount of increase in the motor output based on the constraint conditions received in step S51.
- step S53 the feedback control unit 131 refers to the output increasing means table (see FIG. 5) so as to satisfy the output increasing setting calculated in step S52, and selects the output increasing means.
- the output increase setting is information summarizing the selected output increase means and the setting (intensity or ON / OFF).
- the process of selecting the output increasing means from the output increasing means table shown in FIG. 5 may be performed by the control unit 13 of the work tool 10, or the output increasing means table may be presented to the user or the like for selection. May be urged to.
- step S54 the feedback control unit 131 transmits to the output increase control unit 134 and the output increase mechanism 115 so as to execute the output increase setting according to the selection result in step S53.
- step S55 the output increase control unit 134 executes output increase control (advance angle control, 150-degree energization method control, etc.) based on the output increase setting received from the feedback control unit 131.
- step S56 the output increasing mechanism 115 performs an operation using an output increasing means (orbital, impact hammer, etc.) based on the output increasing setting received from the feedback control unit 131.
- the jigsaw 50 is a work tool for cutting wood and metal by reciprocating the saw blade 52 in the vertical direction at high speed, and as shown in FIG. 10, the main body 51, the saw blade 52, and an orbital ( It is equipped with an output increasing mechanism) 53.
- the reciprocating movement of the saw blade 52 in the vertical direction means the reciprocating movement in the vertical direction in FIG. 11 in the direction of advancing and retreating with respect to the main body 51.
- the main body 51 has a built-in configuration (for example, motor 111, battery 151, etc.) shown in FIG. 1, and the saw blade rotates at a speed corresponding to the pulling amount of the trigger switch 121.
- the 52 is reciprocated up and down.
- the saw blade 52 is a tip tool attached to the tip of the mechanical portion 11, and is attached so as to project downward from the main body portion 51.
- the orbital 53 is arranged in contact with the root portion of the saw blade 52 close to the attachment portion of the saw blade 52 to the main body 51. Then, when the orbital 53 reciprocates in the vertical direction of the saw blade 52, the saw blade 52 is moved in the direction in which the blade is present so that the tip portion of the saw blade 52 moves on the elliptical orbit in the side view shown in FIG. It is a mechanism that pushes out in stages.
- the pressing amount of the saw blade 52 by the orbital 53 is configured to be set in, for example, four steps.
- the stepwise setting is performed by a switching drive unit (motor, solenoid, etc.) (not shown).
- the setting of the orbital 53 can be changed stepwise to carry out the work in consideration of the hardness of the material to be cut by the jigsaw 50, the working speed, and the like.
- the thickness of the metal plate is different.
- the motor load current (load torque) applied to the motor 111 of the work tool 10 is also doubled.
- the thickness of the wooden board is doubled.
- the motor load current (load torque) applied to the motor 111 of the work tool 10 is also doubled.
- the working time of the cutting work is shortened, while the load current (load torque) is increased as well as the thickness of the material to be cut is increased. ..
- the machine output curve and the power efficiency curve are independently measured, output, displayed, and the like according to the above configuration, so that the presence or absence of the performance required by the user can be determined. It can be determined accurately. Then, when looking at the machine output curve and wanting to increase the output, the work tool 10 with the increased machine output can be obtained by utilizing the above-mentioned output increase control and the output increase mechanism.
- the user can compare the high and low power efficiency at the same machine output point, he / she can purchase a more efficient product or purchase a highly efficient control board or motor and replace it (tune-up). ) Can be considered.
- the present invention is not limited to the above embodiment, and various modifications can be made without departing from the gist of the invention.
- the machine output and power efficiency calculated on the work tool 10 side are transmitted from the log output unit 14 to an external terminal 20 such as a PC (Personal Computer), a tablet terminal, or a smartphone, and the external terminal 20 is transmitted.
- an external terminal 20 such as a PC (Personal Computer), a tablet terminal, or a smartphone
- An example of displaying on the display unit 22 of the above has been described.
- the present invention is not limited to this.
- the display unit 222 on the work tool 210 side displays the machine output and power efficiency. It may have such a configuration. At this time, the configuration of the output unit that outputs the mechanical output and the power efficiency to the outside may be deleted. Even in this case, the user or manager of the work tool can check the machine output and power efficiency displayed on the display unit to accurately grasp the performance of the work tool, and if necessary, It is possible to obtain the same effect as described above that the performance can be adjusted to be desired.
- the machine output curve estimation unit 161 corrects the value of the machine output calculated by the machine output calculation unit 161b with the reference machine output stored in the motor characteristic storage unit 161c to obtain accuracy.
- An example of outputting and displaying a high machine output has been described.
- the present invention is not limited to this.
- the value of the machine output calculated by the machine output calculation unit may be output / displayed as the final machine output as it is.
- the power efficiency curve estimation unit 162 corrects the power efficiency value calculated by the power efficiency calculation unit 162c with the reference power efficiency stored in the motor characteristic storage unit 162d to obtain the accuracy.
- An example of outputting and displaying high power efficiency has been described.
- the present invention is not limited to this.
- the value of the power efficiency calculated by the power efficiency calculation unit may be output / displayed as it is as the final power efficiency.
- the present invention is not limited to this.
- the present invention may be applied to a cord-type work tool. Even in this case, for example, by selecting a work tool having high power efficiency (low power consumption) or a work tool having a large machine output, it is possible to provide an optimum work tool for each user.
- control target may be a power consumer equipped with another motor such as a brushed DC motor.
- the present invention may be applied to other work tools such as an electric screwdriver and a chainsaw.
- the work tool of the present invention has the effect of being able to provide the optimum work tool for the user, it can be widely applied to various work tools equipped with a motor.
Landscapes
- Engineering & Computer Science (AREA)
- Life Sciences & Earth Sciences (AREA)
- Mechanical Engineering (AREA)
- Wood Science & Technology (AREA)
- Forests & Forestry (AREA)
- Power Engineering (AREA)
- Physics & Mathematics (AREA)
- Electromagnetism (AREA)
- Control Of Electric Motors In General (AREA)
- Control Of Motors That Do Not Use Commutators (AREA)
- Sawing (AREA)
- Portable Power Tools In General (AREA)
Abstract
作業工具(10)は、モータ(111)と、トリガスイッチ(121)と、測定部(16)とを備えている。トリガスイッチ(121)は、使用者によって操作され、操作量に応じてモータ(111)の出力を調整する。測定部(16)は、トリガスイッチ(121)が操作されて回転するモータの負荷トルクに対する機械出力および電力効率を測定する。
Description
本発明は、例えば、電動ドライバ、ジグソー、チェーンソー等のモータを備えた作業工具およびこれを備えた制御システムに関する。
作業現場や工場において、ドリルやドライバなどの先端工具をモータによって回転駆動して所望の作業を行う電動工具が広く用いられている(例えば、特許文献1参照。)。
このような電動工具の性能は「最大トルク」や、メーカ独自に定められた標準作業を基準として、どれだけ穴あけや切断の回数を行うことができるかを示す「作業量」(○○回、××枚など)で表記されていた。
このような電動工具の性能は「最大トルク」や、メーカ独自に定められた標準作業を基準として、どれだけ穴あけや切断の回数を行うことができるかを示す「作業量」(○○回、××枚など)で表記されていた。
ここで、「最大トルク」は作業効率を、「作業量」はバッテリの持ち(バッテリ残量がなくなって新たなバッテリに交換するまでの時間)を、それぞれ使用者に想起させる。一方、実際の作業効率は、「機械出力」(=回転数×トルク)に略一致し、バッテリの持ちは、「電力効率」に一致する。
しかしながら、上記従来の作業工具では、通常、「機械出力」および「電力効率」の最大点が大きく異なる。このため、「機械出力」を優先すればモータの消費電力が増大してバッテリの持ちは悪くなり、「電力効率」を優先すれば作業に必要なトルクが取り出せないという問題が生じてしまう。
そこで作業工具のメーカは、それぞれが最適なバランス点を設定し、「作業量」を自由に定義していた。よって、使用者は、メーカごとに異なる基準で設定された指標を参照しても、真に「電力効率」の優秀な工具と、単に「機械出力」が大きく出るようにバランス点を取っている工具とを判別することが困難であった。このため、それぞれの使用者にとって最も必要としている作業工具を入手することが難しいという課題があった。
そこで作業工具のメーカは、それぞれが最適なバランス点を設定し、「作業量」を自由に定義していた。よって、使用者は、メーカごとに異なる基準で設定された指標を参照しても、真に「電力効率」の優秀な工具と、単に「機械出力」が大きく出るようにバランス点を取っている工具とを判別することが困難であった。このため、それぞれの使用者にとって最も必要としている作業工具を入手することが難しいという課題があった。
本発明の課題は、使用者にとって最適な作業工具を提供することが可能な作業工具およびこれを備えた制御システムを提供することにある。
第1の発明に係る作業工具は、モータと、トリガスイッチと、機械出力測定部と、電力効率測定部と、を備えている。トリガスイッチは、使用者によって操作され、操作量に応じてモータの出力を調整する。機械出力測定部は、トリガスイッチが操作されて回転するモータの負荷トルクに対する機械出力を測定する。電力効率測定部は、トリガスイッチが操作されて回転するモータの負荷トルクに対する電力効率を測定する。
ここでは、トリガスイッチの操作によって駆動されるモータを搭載した作業工具において、モータの負荷トルクに対する機械出力と電力効率とをそれぞれ測定して、例えば、測定した結果を表示する、あるいは外部機器へ出力する。
ここで、作業工具には、例えば、電動ドライバ、ジグソー、チェーンソー等のモータによって駆動される各種工具が含まれる。
ここで、作業工具には、例えば、電動ドライバ、ジグソー、チェーンソー等のモータによって駆動される各種工具が含まれる。
機械出力とは、モータの負荷トルクに対する機械出力であって、モータの回転数×トルクによって算出される。
電力効率とは、モータの負荷トルクに対する電力効率であって、モータによる単位時間当たりの消費電力量、すなわち、バッテリ駆動式のモータの場合はバッテリの持ち(バッテリ残量が無くなって新たなバッテリに交換するまでの時間)を意味する。
電力効率とは、モータの負荷トルクに対する電力効率であって、モータによる単位時間当たりの消費電力量、すなわち、バッテリ駆動式のモータの場合はバッテリの持ち(バッテリ残量が無くなって新たなバッテリに交換するまでの時間)を意味する。
そして、本作業工具では、モータの負荷トルクに対する機械出力と電力効率とを、それぞれ別々に測定し、機械出力と電力効率とを、例えば、表示する、あるいは外部機器等へ出力することを主な特徴としている。
これにより、作業工具の使用者あるいは管理者等に対して、その作業工具の性能として、機械出力および電力効率を分離して表示、出力等することができる。
この結果、使用者や管理者は、その作業工具の性能を認識した上で、そのまま使用する、あるいは、必要な調整を行う等することで、使用者にとって最適な作業工具を提供することができる。
これにより、作業工具の使用者あるいは管理者等に対して、その作業工具の性能として、機械出力および電力効率を分離して表示、出力等することができる。
この結果、使用者や管理者は、その作業工具の性能を認識した上で、そのまま使用する、あるいは、必要な調整を行う等することで、使用者にとって最適な作業工具を提供することができる。
第2の発明に係る作業工具は、第1の発明に係る作業工具であって、機械出力測定部において測定された機械出力と、電力効率測定部において測定された電力効率と、をそれぞれ表示する表示部を、さらに備えている。
ここでは、測定された機械出力と電力効率とを、作業工具に設けられた表示部に表示させる。
これにより、使用者は、表示部に表示された機械出力と電力効率とを確認して、その作業工具の性能を正確に認識することができるとともに、機械出力と電力効率とのバランスを考慮しながら、最適なバランスになるように、モータの制約条件を設定することができる。
この結果、使用者は、作業工具の機械出力および電力効率を正確に認識して使用することができるとともに、使用者の要望に応じて設定された制約条件によってモータが駆動される所望の性能を持った作業工具を提供することができる。
これにより、使用者は、表示部に表示された機械出力と電力効率とを確認して、その作業工具の性能を正確に認識することができるとともに、機械出力と電力効率とのバランスを考慮しながら、最適なバランスになるように、モータの制約条件を設定することができる。
この結果、使用者は、作業工具の機械出力および電力効率を正確に認識して使用することができるとともに、使用者の要望に応じて設定された制約条件によってモータが駆動される所望の性能を持った作業工具を提供することができる。
第3の発明に係る作業工具は、第1または第2の発明に係る作業工具であって、機械出力測定部において測定された機械出力と、電力効率測定部において測定された電力効率とを、外部へ出力する出力部を、さらに備えている。
ここでは、測定された機械出力と電力効率とを、例えば、PC(Personal Computer)、スマートフォン、タブレット端末等の外部機器等へ出力する。
ここでは、測定された機械出力と電力効率とを、例えば、PC(Personal Computer)、スマートフォン、タブレット端末等の外部機器等へ出力する。
これにより、使用者は、PC等の外部機器の表示画面に表示された機械出力と電力効率とを確認して、その作業工具の性能を正確に認識することができるとともに、機械出力と電力効率とのバランスを考慮しながら、最適なバランスになるように、モータの制約条件を設定することができる。
この結果、使用者は、作業工具の機械出力および電力効率を正確に認識して使用することができるとともに、使用者の要望に応じて設定された制約条件によってモータが駆動される所望の性能を持った作業工具を提供することができる。
この結果、使用者は、作業工具の機械出力および電力効率を正確に認識して使用することができるとともに、使用者の要望に応じて設定された制約条件によってモータが駆動される所望の性能を持った作業工具を提供することができる。
第4の発明に係る作業工具は、第1から第3の発明のいずれか1つに係る作業工具であって、機械出力測定部は、モータに流れるモータ電流からモータの負荷トルクを算出する負荷トルク算出部と、負荷トルク算出部において算出された負荷トルクとモータの回転速度とに基づいて第1機械出力を算出する第1算出部と、を有している。
ここでは、機械出力を算出する際に、トリガスイッチが操作されてモータに流れるモータ電流からモータの負荷トルクを算出し、算出された負荷トルクとモータの回転速度とに基づいて機械出力(第1機械出力)を算出する。
これにより、実際にトリガスイッチを操作されて検出されるモータ電流から負荷トルクを算出し、この負荷トルクとモータの回転速度とに基づいて、機械出力の実測値を算出することができる。
これにより、実際にトリガスイッチを操作されて検出されるモータ電流から負荷トルクを算出し、この負荷トルクとモータの回転速度とに基づいて、機械出力の実測値を算出することができる。
第5の発明に係る作業工具は、第4の発明に係る作業工具であって、機械出力測定部は、第1算出部において算出された第1機械出力と、モータの機械出力の基準となる基準機械出力とを比較して、第1機械出力と基準機械出力との差分に基づいて、第1機械出力を補正する第1補正部を、さらに有している。
ここでは、上記第1算出部において算出された第1機械出力と、モータの機械出力の基準値(基準機械出力)とを比較し、その差分に基づいて、第1機械出力を補正する。
ここでは、上記第1算出部において算出された第1機械出力と、モータの機械出力の基準値(基準機械出力)とを比較し、その差分に基づいて、第1機械出力を補正する。
ここで、モータの機械出力の基準となる基準機械出力は、作業工具に搭載されたモータの特性によって決まる基準値であって、例えば、予め作業工具の記憶部内に保存されていてもよいし、通信によって外部から受信してもよい。
これにより、測定された機械出力の値を補正することで、例えば、表示される、あるいは外部機器等へ出力される機械出力の精度を高めることができる。
これにより、測定された機械出力の値を補正することで、例えば、表示される、あるいは外部機器等へ出力される機械出力の精度を高めることができる。
第6の発明に係る作業工具は、第1から第5の発明のいずれか1つに係る作業工具であって、電力効率測定部は、モータに入力される入力電力とモータから出力された出力電力と、モータの負荷トルクとに基づいて、第1電力効率を算出する第2算出部を、有している。
ここでは、電力効率を算出する際に、モータに入力される入力電力およびモータから出力された出力電力と、モータの負荷トルクとに基づいて電力効率(第1電力効率)を算出する。
これにより、実際にトリガスイッチを操作されて検出される入力電力および出力電力と、モータの負荷トルクとに基づいて、電力効率の実測値を算出することができる。
ここでは、電力効率を算出する際に、モータに入力される入力電力およびモータから出力された出力電力と、モータの負荷トルクとに基づいて電力効率(第1電力効率)を算出する。
これにより、実際にトリガスイッチを操作されて検出される入力電力および出力電力と、モータの負荷トルクとに基づいて、電力効率の実測値を算出することができる。
第7の発明に係る作業工具は、第6の発明に係る作業工具であって、電力効率測定部は、第2算出部において算出された第1電力効率と、モータの電力効率の基準となる基準電力効率とを比較して、第1電力効率と基準電力効率との差分に基づいて、第1電力効率を補正する第2補正部を、さらに有している。
ここでは、上記第2算出部において算出された第1電力効率と、モータの電力効率の基準値(基準電力効率)とを比較し、その差分に基づいて、第1電力効率を補正する。
ここで、モータの電力効率の基準となる基準電力効率は、作業工具に搭載されたモータの特性によって決められる基準値であって、例えば、予め作業工具の記憶部内に保存されていてもよいし、通信によって外部から受信してもよい。
これにより、測定された電力効率の値を補正することで、例えば、表示される、あるいは外部機器等へ出力される電力効率の精度を高めることができる。
ここで、モータの電力効率の基準となる基準電力効率は、作業工具に搭載されたモータの特性によって決められる基準値であって、例えば、予め作業工具の記憶部内に保存されていてもよいし、通信によって外部から受信してもよい。
これにより、測定された電力効率の値を補正することで、例えば、表示される、あるいは外部機器等へ出力される電力効率の精度を高めることができる。
第8の発明に係る作業工具は、第1から第7の発明のいずれか1つに係る作業工具であって、モータの出力を増加させる出力増加制御部を、さらに備えている。
ここでは、モータの出力を増加させる手段として、例えば、PWM(Pulse Width Modulation)制御等の出力増加制御を実施する。
これにより、モータ制御の観点からモータの出力を増加させることで、使用者が求める性能(機械出力)を作業工具に持たせることができる。
ここでは、モータの出力を増加させる手段として、例えば、PWM(Pulse Width Modulation)制御等の出力増加制御を実施する。
これにより、モータ制御の観点からモータの出力を増加させることで、使用者が求める性能(機械出力)を作業工具に持たせることができる。
第9の発明に係る作業工具は、第8の発明に係る作業工具であって、出力増加制御部は、PWM制御、進角制御、150度通電方式制御のうちの少なくとも1つを実施する。
ここでは、上述したモータ出力増加制御として、PWM制御、進角制御、150度通電方式制御のうちの少なくとも1つを実施する。
これにより、これらのモータ制御を選択して、あるいは組み合わせて、モータの出力を増加させることができる。
ここでは、上述したモータ出力増加制御として、PWM制御、進角制御、150度通電方式制御のうちの少なくとも1つを実施する。
これにより、これらのモータ制御を選択して、あるいは組み合わせて、モータの出力を増加させることができる。
第10の発明に係る作業工具は、第1から第9の発明のいずれか1つに係る作業工具であって、機械出力を増加させる機械出力増加機構を、さらに備えている。
ここでは、モータの出力を増加させる手段として、機械出力を機構的に増加させることが可能な機械出力増加機構が設けられている。
これにより、機構的な側面からモータの出力を増加させることで、使用者が求める性能(機械出力)を作業工具に持たせることができる。
ここでは、モータの出力を増加させる手段として、機械出力を機構的に増加させることが可能な機械出力増加機構が設けられている。
これにより、機構的な側面からモータの出力を増加させることで、使用者が求める性能(機械出力)を作業工具に持たせることができる。
第11の発明に係る作業工具は、第10の発明に係る作業工具であって、機械出力増加機構は、オービタルあるいはインパクトハンマである。
ここでは、例えば、ジグソー等の作業工具の機械出力増加機構として用いられるオービタル、あるいは電動ドライバ等の作業工具の機械出力増加機構として用いられるインパクトハンマによって、作業工具の機械出力を増加させる。
これにより、各種作業工具の機械出力を、機構的な側面から増加させることができる。
ここでは、例えば、ジグソー等の作業工具の機械出力増加機構として用いられるオービタル、あるいは電動ドライバ等の作業工具の機械出力増加機構として用いられるインパクトハンマによって、作業工具の機械出力を増加させる。
これにより、各種作業工具の機械出力を、機構的な側面から増加させることができる。
第12の発明に係る作業工具は、第1から第11の発明のいずれか1つに係る作業工具であって、機械出力および電力効率に基づいて設定された制約条件のもとで、フィードバック制御を行うフィードバック制御部を、さらに備えている。
これにより、例えば、表示あるいは外部機器等へ出力された機械出力および電力効率を使用者が変更し、変更後の機械出力および電力効率に基づいてPC等の外部端末等において設定された制約条件を受信し、その制約条件のもとで、モータのフィードバック制御を実施することができる。
この結果、使用者の要求に応じた機械出力および電力効率を持つ作業工具を提供することができる。
これにより、例えば、表示あるいは外部機器等へ出力された機械出力および電力効率を使用者が変更し、変更後の機械出力および電力効率に基づいてPC等の外部端末等において設定された制約条件を受信し、その制約条件のもとで、モータのフィードバック制御を実施することができる。
この結果、使用者の要求に応じた機械出力および電力効率を持つ作業工具を提供することができる。
第13の発明に係る作業工具は、第1から第12の発明のいずれか1つに係る作業工具であって、モータの制御に関する値を検出するセンサを、さらに備えている。
これにより、モータの制御に関する各種データを、各種センサを用いて取得することができる。
これにより、モータの制御に関する各種データを、各種センサを用いて取得することができる。
第14の発明に係る作業工具は、第13の発明に係る作業工具であって、センサは、トリガスイッチの操作量を検出するセンサ、モータに印加される電圧を検出する電圧センサ、モータに流れる電流を検出する電流センサ、モータの温度を検出する温度センサを含む。
これにより、トリガスイッチの操作量を検出するセンサ、モータの電圧センサ、電流センサ、温度センサ等における検出結果を取得することができる。
この結果、これらのデータを用いて、例えば、作業工具のフィードバック制御を実施することで、使用者にとって、より使い勝手のよい作業工具を提供することができる。
これにより、トリガスイッチの操作量を検出するセンサ、モータの電圧センサ、電流センサ、温度センサ等における検出結果を取得することができる。
この結果、これらのデータを用いて、例えば、作業工具のフィードバック制御を実施することで、使用者にとって、より使い勝手のよい作業工具を提供することができる。
第15の発明に係る作業工具は、第1から第14の発明のいずれか1つに係る作業工具であって、モータは、ブラシレスモータである。
これにより、長寿命で小型化が可能であり高出力、高効率という特徴を持つブラシレスモータを備え、使用者にとって使い勝手よい作業工具を提供することができる。
これにより、長寿命で小型化が可能であり高出力、高効率という特徴を持つブラシレスモータを備え、使用者にとって使い勝手よい作業工具を提供することができる。
第16の発明に係る制御システムは、第1から第15の発明のいずれか1つに係る作業工具と、機械出力および電力効率を保存する記憶部と機械出力および電力効率に基づく情報を表示する表示部とを有する外部端末と、を備えている。
ここで、外部端末には、使用者や管理者が使用するPC(Personal Computer)、タブレット端末、スマートフォン等が含まれる。
ここで、外部端末には、使用者や管理者が使用するPC(Personal Computer)、タブレット端末、スマートフォン等が含まれる。
これにより、作業工具から出力された機械出力および電力効率のデータを、外部端末側の記憶部に保存するとともに、保存されたデータを表示部に表示させることで、例えば、使用者あるいは管理者は、外部端末の表示部に表示された機械出力および電力効率を示すデータやグラフ等を見ながら、より適切な制約条件等を設定することができる。
この結果、使用者にとって使い勝手のよい作業工具を提供することができる。
この結果、使用者にとって使い勝手のよい作業工具を提供することができる。
(発明の効果)
本発明に係る作業工具によれば、使用者にとって最適な作業工具を提供することができる。
本発明に係る作業工具によれば、使用者にとって最適な作業工具を提供することができる。
本発明の一実施形態に係る作業工具10およびこれを備えた制御システム100について、図1~図13(b)を用いて説明すれば以下の通りである。
(制御システム100の概要)
図1は、本実施形態の制御システム100の構成を示すブロック図である。
本実施形態の制御システム100は、図1に示すように、作業工具10と、外部端末20と、を備えている。作業工具10は、例えば、ジグソー、チェーンソー、電動ドライバ等のモータ111によって駆動される工具である。外部端末20は、例えば、作業工具10に搭載されたモータ111の駆動に関する制御値のログデータや作業工具10の機械出力および電力効率等を表示するとともに、その後の制御の制約条件等が設定される。
(制御システム100の概要)
図1は、本実施形態の制御システム100の構成を示すブロック図である。
本実施形態の制御システム100は、図1に示すように、作業工具10と、外部端末20と、を備えている。作業工具10は、例えば、ジグソー、チェーンソー、電動ドライバ等のモータ111によって駆動される工具である。外部端末20は、例えば、作業工具10に搭載されたモータ111の駆動に関する制御値のログデータや作業工具10の機械出力および電力効率等を表示するとともに、その後の制御の制約条件等が設定される。
なお、機械出力とは、例えば、モータ111の負荷トルクに対する作業工具10の機械出力であって、モータ111の回転数×トルクによって算出される。
そして、電力効率とは、例えば、モータ111の負荷トルクに対する作業工具10の電力効率であって、モータ111による単位時間当たりの消費電力量を意味している。よって、本実施形態のように、交換可能なバッテリ151から電力が供給されるバッテリ駆動式のモータ111の場合には、バッテリ151の持ち(バッテリ残量が無くなって新たなバッテリに交換するまでの時間)を意味する。
そして、電力効率とは、例えば、モータ111の負荷トルクに対する作業工具10の電力効率であって、モータ111による単位時間当たりの消費電力量を意味している。よって、本実施形態のように、交換可能なバッテリ151から電力が供給されるバッテリ駆動式のモータ111の場合には、バッテリ151の持ち(バッテリ残量が無くなって新たなバッテリに交換するまでの時間)を意味する。
(作業工具10)
作業工具10は、モータ111を搭載した電力消費体の一種であって、図1に示すように、機構部11と、入力部12と、制御部13と、ログ出力部14と、電源部15と、測定部16と、を備えている。
機構部11は、ジグソーの鋸刃などの工具を駆動する。
作業工具10は、モータ111を搭載した電力消費体の一種であって、図1に示すように、機構部11と、入力部12と、制御部13と、ログ出力部14と、電源部15と、測定部16と、を備えている。
機構部11は、ジグソーの鋸刃などの工具を駆動する。
入力部12は、作業工具10に設けられた各種センサによって検出された値を、制御部13へと送信する。
制御部13は、入力部12からの入力情報などに基づいて機構部11の駆動の制御を行う。
ログ出力部14は、駆動時における制御値のログデータ、測定部16において測定された機械出力および電力効率のデータを外部端末20に送信する。
電源部15は、機構部11、入力部12、制御部13、ログ出力部14および測定部16に対して、電力を供給する。
制御部13は、入力部12からの入力情報などに基づいて機構部11の駆動の制御を行う。
ログ出力部14は、駆動時における制御値のログデータ、測定部16において測定された機械出力および電力効率のデータを外部端末20に送信する。
電源部15は、機構部11、入力部12、制御部13、ログ出力部14および測定部16に対して、電力を供給する。
(機構部11)
機構部11は、図1に示すように、モータ111と、減速機112と、出力部113と、位置検出部114と、出力増加機構(機械出力増加機構)115と、を有している。
機構部11は、図1に示すように、モータ111と、減速機112と、出力部113と、位置検出部114と、出力増加機構(機械出力増加機構)115と、を有している。
モータ111は、制御部13からの指示に基づいて回転駆動される。モータ111としては、例えば、三相DCブラシレスモータを用いることができる。
減速機112は、ギア機構などによって構成されており、モータ111のトルクを増幅する。減速機112とモータ111との間は、回転の同期がとられており、モータ111の回転を減速して出力部113へと伝達する。
減速機112は、ギア機構などによって構成されており、モータ111のトルクを増幅する。減速機112とモータ111との間は、回転の同期がとられており、モータ111の回転を減速して出力部113へと伝達する。
出力部113は、例えば、ジグソー鋸刃等であって、切断等の目的に応じてモータ111の出力を機械的な仕事に変換する。減速機112と出力部113との間は、回転の同期が取られており、モータ111の回転を出力する。
位置検出部114は、ホールICに代表される磁気センサ等である。位置検出部114は、モータ111の回転角度位置を検出し、制御部13へ送信する。位置検出部114は、センサを用いない構成であってもよく、電流を検出することによりモータ111の回転角度位置を検出する。位置検出部114とモータ111の間において回転の同期がとられている。
出力増加機構115は、例えば、作業工具10がジグソーである場合に、鋸刃付近に装着されるオービタル、作業工具10が電動ドライバである場合に、先端部付近に装着されるインパクトハンマ等を含む機構であって、それぞれ、作業工具10の機械出力を増加させる。
位置検出部114は、ホールICに代表される磁気センサ等である。位置検出部114は、モータ111の回転角度位置を検出し、制御部13へ送信する。位置検出部114は、センサを用いない構成であってもよく、電流を検出することによりモータ111の回転角度位置を検出する。位置検出部114とモータ111の間において回転の同期がとられている。
出力増加機構115は、例えば、作業工具10がジグソーである場合に、鋸刃付近に装着されるオービタル、作業工具10が電動ドライバである場合に、先端部付近に装着されるインパクトハンマ等を含む機構であって、それぞれ、作業工具10の機械出力を増加させる。
(入力部12)
入力部12は、図1に示すように、トリガスイッチ121と、センサ回路122と、を有している。
入力部12は、図1に示すように、トリガスイッチ121と、センサ回路122と、を有している。
トリガスイッチ121は、アナログスイッチであって、作業工具10の持ち手部分に設けられており、その引き量(操作量)に応じてモータ111の出力を調整する。
センサ回路122は、入力されたトリガスイッチ121の引き量を、制御部13へと送信する。センサ回路122は、引き量センサ122aと、電圧センサ122bと、電流センサ122cと、トルクセンサ122dと、温度センサ122eとを含む。
センサ回路122は、入力されたトリガスイッチ121の引き量を、制御部13へと送信する。センサ回路122は、引き量センサ122aと、電圧センサ122bと、電流センサ122cと、トルクセンサ122dと、温度センサ122eとを含む。
引き量センサ122aは、トリガスイッチ121の引き量(操作量)を検出する。
電圧センサ122bは、モータ111への印加される電圧を検出する。
電流センサ122cは、モータ111に流れる電流を検出する。
トルクセンサ122dは、例えば、作業工具10を用いて所定の材料にボルト止め作業を実施する際に、モータ111の回転時に生じるトルクを検出する。
温度センサ122eは、モータ111等の温度を検出する。
なお、センサ回路122は、これらのセンサ以外のセンサ、例えば、周囲環境を計測するセンサ(湿度センサ)等を含んでいてもよい。
電圧センサ122bは、モータ111への印加される電圧を検出する。
電流センサ122cは、モータ111に流れる電流を検出する。
トルクセンサ122dは、例えば、作業工具10を用いて所定の材料にボルト止め作業を実施する際に、モータ111の回転時に生じるトルクを検出する。
温度センサ122eは、モータ111等の温度を検出する。
なお、センサ回路122は、これらのセンサ以外のセンサ、例えば、周囲環境を計測するセンサ(湿度センサ)等を含んでいてもよい。
(制御部13)
制御部13は、図1に示すように、作業工具10と通信可能な外部端末20によって設定された制約条件に基づいて、機構部11の駆動を制御する。制御部13は、フィードバック制御部131と、モータ駆動回路132と、回転速度演算部133と、出力増加制御部134と、を有している。
制御部13は、図1に示すように、作業工具10と通信可能な外部端末20によって設定された制約条件に基づいて、機構部11の駆動を制御する。制御部13は、フィードバック制御部131と、モータ駆動回路132と、回転速度演算部133と、出力増加制御部134と、を有している。
フィードバック制御部131は、使用者によるトリガスイッチ121の引き量(操作量)に応じて、外部端末20から受信した制約条件のもとで、センサ回路122から入力される各種センサ情報と、回転速度演算部133から入力される回転角度位置および回転速度とに基づいて、PWM(Pulse Width Modulation)信号の出力を決定する。
なお、制約条件とは、目標値(固定値)、上下値リミッタ、目標値テーブル、シーケンス動作などであって、後述する外部端末20において設定され、作業工具10へ送信される。そして、フィードバック制御部131は、モータ駆動回路132にPWM信号を送信する。
なお、制約条件とは、目標値(固定値)、上下値リミッタ、目標値テーブル、シーケンス動作などであって、後述する外部端末20において設定され、作業工具10へ送信される。そして、フィードバック制御部131は、モータ駆動回路132にPWM信号を送信する。
フィードバック制御部131から送信されるPWM信号は、トリガスイッチ121の引き量等に応じて決定され、例えば、90%、50%、10%等である。これにより、トリガスイッチ121の引き量等に応じて、モータの出力を調整することができる。
モータ駆動回路132は、機構部11の位置検出部114で検出された回転角度位置に応じて転流動作を行うとともに、フィードバック制御部131から入力されるPWM信号によるONデューティ比に基づいてモータ111のUVW相に印加される平均電圧を切り替える。
モータ駆動回路132は、機構部11の位置検出部114で検出された回転角度位置に応じて転流動作を行うとともに、フィードバック制御部131から入力されるPWM信号によるONデューティ比に基づいてモータ111のUVW相に印加される平均電圧を切り替える。
回転速度演算部133は、機構部11の位置検出部114で検出された出力パルス間隔からモータ111の回転速度を算出する。そして、回転速度演算部133は、位置検出部114から入力された回転角度位置と演算した回転速度とを、フィードバック制御部131に送信する。
出力増加制御部134は、フィードバック制御部131から入力された出力増加設定に基づいて、モータ111の出力を制御面から増加させるように制御を行う。具体的には、出力増加制御部134は、進角制御、150度通電方式制御等を実施するように、モータ駆動回路132へ出力増加制御信号を送信することで、モータ111の出力を増加させる。
なお、本実施形態において、モータ111の出力を増加させる制御としては、フィードバック制御部131によって実施されるPWM制御も含まれる。
出力増加制御部134は、フィードバック制御部131から入力された出力増加設定に基づいて、モータ111の出力を制御面から増加させるように制御を行う。具体的には、出力増加制御部134は、進角制御、150度通電方式制御等を実施するように、モータ駆動回路132へ出力増加制御信号を送信することで、モータ111の出力を増加させる。
なお、本実施形態において、モータ111の出力を増加させる制御としては、フィードバック制御部131によって実施されるPWM制御も含まれる。
(ログ出力部14)
ログ出力部14は、図1に示すように、各種制御量のデータと、後述する作業工具10の機械出力および電力効率とを、外部端末20に送信する。各種制御量には、目標値(例えば、回転速度)、出力値(例えば、Duty比)、およびセンサの値(上述した各種センサの検出値、例えば、トリガ引き量)が含まれる。
ログ出力部14には、センサ回路122で検出された各種センサの値、フィードバック制御部131で決定されたPWM出力、回転速度演算部133で演算された回転位置・回転速度、および位置検出部114で検出された回転角度位置、測定部16において測定された機械出力および電力効率等の各種データが入力される。
ログ出力部14は、図1に示すように、各種制御量のデータと、後述する作業工具10の機械出力および電力効率とを、外部端末20に送信する。各種制御量には、目標値(例えば、回転速度)、出力値(例えば、Duty比)、およびセンサの値(上述した各種センサの検出値、例えば、トリガ引き量)が含まれる。
ログ出力部14には、センサ回路122で検出された各種センサの値、フィードバック制御部131で決定されたPWM出力、回転速度演算部133で演算された回転位置・回転速度、および位置検出部114で検出された回転角度位置、測定部16において測定された機械出力および電力効率等の各種データが入力される。
(電源部15)
電源部15は、機構部11、入力部12、制御部13、ログ出力部14および測定部16に対して電力を供給する。そして、電源部15は、バッテリ151と、バッテリ制御部152とを有している。
バッテリ151は、交換可能な二次電池であって、例えば、18Vのリチウムイオンバッテリ等が用いられる。
バッテリ制御部152は、リチウムイオンバッテリ等のバッテリ151を充放電するための電子回路である。
電源部15は、機構部11、入力部12、制御部13、ログ出力部14および測定部16に対して電力を供給する。そして、電源部15は、バッテリ151と、バッテリ制御部152とを有している。
バッテリ151は、交換可能な二次電池であって、例えば、18Vのリチウムイオンバッテリ等が用いられる。
バッテリ制御部152は、リチウムイオンバッテリ等のバッテリ151を充放電するための電子回路である。
(測定部16)
測定部16は、図1に示すように、モータ電圧およびモータ電流、バッテリ電圧およびバッテリ電流、モータ111の回転速度等のデータが入力され、機械出力曲線と電力効率曲線とを推定する。より詳細には、測定部16は、図2に示すように、機械出力曲線推定部(機械出力測定部)161と、電力効率曲線推定部(電力効率測定部)162とを有している。
測定部16は、図1に示すように、モータ電圧およびモータ電流、バッテリ電圧およびバッテリ電流、モータ111の回転速度等のデータが入力され、機械出力曲線と電力効率曲線とを推定する。より詳細には、測定部16は、図2に示すように、機械出力曲線推定部(機械出力測定部)161と、電力効率曲線推定部(電力効率測定部)162とを有している。
機械出力曲線推定部161は、入力されるモータ電流と、モータ111の回転速度とに基づいて推定された機械出力曲線を、ログ出力部14へ送信する。具体的には、機械出力曲線推定部161は、図2に示すように、負荷トルク算出部161a、機械出力算出部(第1算出部)161b、モータ特性記憶部161c、基準曲線取得部161d、機械出力差分算出部161e、曲線推定部(第1補正部)161fを有している。
負荷トルク算出部161aは、トリガスイッチ121の操作量に応じてモータ駆動回路132から送信されたモータ電流を受信して、モータ111の負荷トルクを算出し、機械出力算出部161bへ送信する。
機械出力算出部(第1算出部)161bは、負荷トルク算出部161aから受信した負荷トルクと、回転速度演算部133から入力されたモータ111の回転速度とに基づいて、暫定値として実測の機械出力(第1機械出力)を算出する。そして、機械出力算出部161bは、負荷トルクと実測の機械出力(第1機械出力)とを、機械出力差分算出部161eへ送信する。
機械出力算出部(第1算出部)161bは、負荷トルク算出部161aから受信した負荷トルクと、回転速度演算部133から入力されたモータ111の回転速度とに基づいて、暫定値として実測の機械出力(第1機械出力)を算出する。そして、機械出力算出部161bは、負荷トルクと実測の機械出力(第1機械出力)とを、機械出力差分算出部161eへ送信する。
モータ特性記憶部161cは、作業工具10に搭載されたモータ111の特性データを保存しており、基準曲線取得部161dへモータ特性のデータを送信する。
基準曲線取得部161dは、モータ特性記憶部161cからモータ111の特性データを読み出して、機械出力基準曲線(基準機械出力)を取得し、機械出力基準曲線を機械出力差分算出部161eへ送信する。
基準曲線取得部161dは、モータ特性記憶部161cからモータ111の特性データを読み出して、機械出力基準曲線(基準機械出力)を取得し、機械出力基準曲線を機械出力差分算出部161eへ送信する。
機械出力差分算出部161eは、機械出力算出部161bから受信した暫定値としての機械出力(第1機械出力)と基準曲線取得部161dから受信した機械出力基準曲線(基準機械出力)とを比較した差分を、曲線推定部161fへ送信する。
曲線推定部(第1補正部)161fは、機械出力差分算出部161eから受信した差分に基づいて、機械出力算出部161bから受信した暫定値としての機械出力(第1機械出力)を補正することで、精度の高い機械出力曲線を推定して、ログ出力部14へ送信する。
曲線推定部(第1補正部)161fは、機械出力差分算出部161eから受信した差分に基づいて、機械出力算出部161bから受信した暫定値としての機械出力(第1機械出力)を補正することで、精度の高い機械出力曲線を推定して、ログ出力部14へ送信する。
本実施形態の作業工具10では、以上のように、電力効率とは分離して機械出力曲線を測定し、ログ出力部14を介して、外部端末20等へ出力することができる。
電力効率曲線推定部162は、入力されるモータ電圧・モータ電流およびバッテリ電圧・バッテリ電流と、負荷トルクとに基づいて推定された電力効率曲線を、ログ出力部14へ送信する。具体的には、電力効率曲線推定部162は、図2に示すように、出力電力算出部162a、入力電力算出部162b、電力効率算出部(第2算出部)162c、モータ特性記憶部162d、基準曲線取得部162e、電力効率差分算出部162f、曲線推定部(第2補正部)161gを有している。
電力効率曲線推定部162は、入力されるモータ電圧・モータ電流およびバッテリ電圧・バッテリ電流と、負荷トルクとに基づいて推定された電力効率曲線を、ログ出力部14へ送信する。具体的には、電力効率曲線推定部162は、図2に示すように、出力電力算出部162a、入力電力算出部162b、電力効率算出部(第2算出部)162c、モータ特性記憶部162d、基準曲線取得部162e、電力効率差分算出部162f、曲線推定部(第2補正部)161gを有している。
出力電力算出部162aは、モータ111から出力されるモータ電圧・モータ電流を受信して、モータ111から出力される出力電力を、電力効率算出部162cへ送信する。
入力電力算出部162bは、バッテリ151からモータ111に対して入力されるモータ電圧・モータ電流を受信して、モータ111へ入力される入力電力を、電力効率算出部162cへ送信する。
入力電力算出部162bは、バッテリ151からモータ111に対して入力されるモータ電圧・モータ電流を受信して、モータ111へ入力される入力電力を、電力効率算出部162cへ送信する。
電力効率算出部(第2算出部)162cは、出力電力算出部162aおよび入力電力算出部162bから受信した出力電力および入力電力と、機械出力曲線推定部161の負荷トルク算出部161aから受信した負荷トルクとに基づいて、モータ111の暫定値としての電力効率(第1電力効率)を算出する。そして、電力効率算出部162cは、負荷トルクと実測の電力効率(第1電力効率)とを、電力効率差分算出部162fへ送信する。
モータ特性記憶部162dは、作業工具10に搭載されたモータ111の特性データを保存しており、基準曲線取得部162eへモータ特性のデータを送信する。
なお、機械出力曲線推定部161側のモータ特性記憶部161cと、電力効率曲線推定部162側のモータ特性記憶部162dとは、共通の記憶部として構成されていてもよい。
なお、機械出力曲線推定部161側のモータ特性記憶部161cと、電力効率曲線推定部162側のモータ特性記憶部162dとは、共通の記憶部として構成されていてもよい。
基準曲線取得部162eは、モータ特性記憶部162dからモータ111の特性データを読み出して、電力効率基準曲線(基準電力効率)を取得し、電力効率基準曲線を電力効率差分算出部162fへ送信する。
電力効率差分算出部162fは、電力効率算出部162cから受信した暫定値としての電力効率(第1電力効率)と基準曲線取得部162eから受信した電力効率基準曲線(基準電力効率)とを比較した差分を、曲線推定部162gへ送信する。
電力効率差分算出部162fは、電力効率算出部162cから受信した暫定値としての電力効率(第1電力効率)と基準曲線取得部162eから受信した電力効率基準曲線(基準電力効率)とを比較した差分を、曲線推定部162gへ送信する。
曲線推定部(第2補正部)162gは、電力効率差分算出部162fから受信した差分に基づいて、電力効率算出部162cから受信した暫定値としての電力効率(第1電力効率)を補正することで、精度の高い電力効率曲線を推定して、ログ出力部14へ送信する。
本実施形態の作業工具10では、以上のように、機械出力とは分離して電力効率曲線を測定し、ログ出力部14を介して、外部端末20等へ出力することができる。
本実施形態の作業工具10では、以上のように、機械出力とは分離して電力効率曲線を測定し、ログ出力部14を介して、外部端末20等へ出力することができる。
(外部端末20)
外部端末20は、使用者や管理者が使用する端末(例えば、作業工具10と通信可能なPC(Personal Computer)等)であって、作業工具10のログ出力部14から出力されたデータに基づいて、作業工具10の制約条件を設定する。そして、外部端末20は、上述した作業工具10から出力された機械出力曲線および電力効率曲線を受信して、表示部22に表示させる。
外部端末20は、使用者や管理者が使用する端末(例えば、作業工具10と通信可能なPC(Personal Computer)等)であって、作業工具10のログ出力部14から出力されたデータに基づいて、作業工具10の制約条件を設定する。そして、外部端末20は、上述した作業工具10から出力された機械出力曲線および電力効率曲線を受信して、表示部22に表示させる。
より詳細には、外部端末20は、記憶部21と、表示部22と、設定部23と、を有している。
記憶部21は、作業工具10のログ出力部14から送信されたログデータ、作業工具10の機械出力曲線および電力効率曲線を受信して保存する。なお、外部端末20と作業工具10との間の通信は、有線・無線等の様々な手段を用いることができる。通信手段は、特に限定されるものではないが、無線で行われることが好ましく、インターネットを介した通信であってもよい。
記憶部21は、作業工具10のログ出力部14から送信されたログデータ、作業工具10の機械出力曲線および電力効率曲線を受信して保存する。なお、外部端末20と作業工具10との間の通信は、有線・無線等の様々な手段を用いることができる。通信手段は、特に限定されるものではないが、無線で行われることが好ましく、インターネットを介した通信であってもよい。
表示部22は、記憶部21に記憶されているログデータあるいはその波形を表示するとともに、作業工具10の制約条件を設定する設定画面を表示する。さらに、表示部22は、上述した作業工具10において、別々に測定され、出力された機械出力曲線および電力効率曲線を受信して、それぞれの曲線を表示させる。
これにより、表示部22では、機械出力曲線および電力効率曲線を確認して、機械出力と電力効率とのバランス点を表示することができる。
これにより、表示部22では、機械出力曲線および電力効率曲線を確認して、機械出力と電力効率とのバランス点を表示することができる。
設定部23は、ログ出力部14から出力された各種制御量のログデータ、機械出力曲線および電力効率曲線を確認した使用者等による上記バランス点の変更、あるいは制約条件の設定変更に基づいて、所定の制御値に対して制約条件を設定し、作業工具10のフィードバック制御部131に送信する。
図3は、外部端末20に含まれる表示部22の表示画面に表示される負荷トルクに対する機械出力曲線と電力効率曲線の一例を示す図である。図3では、実線で示す電力効率曲線と、破線で示す機械出力曲線とでは、ピークとなる位置の負荷トルクの大きさが異なっている。このため、例えば、A点とB点とを比較すると、A点では、B点よりも電力効率は上昇するものの、機械出力はB点よりも小さくなる。一方、B点では、A点よりも電力効率は低下するものの、機械出力はA点よりも大きくなる。
図3は、外部端末20に含まれる表示部22の表示画面に表示される負荷トルクに対する機械出力曲線と電力効率曲線の一例を示す図である。図3では、実線で示す電力効率曲線と、破線で示す機械出力曲線とでは、ピークとなる位置の負荷トルクの大きさが異なっている。このため、例えば、A点とB点とを比較すると、A点では、B点よりも電力効率は上昇するものの、機械出力はB点よりも小さくなる。一方、B点では、A点よりも電力効率は低下するものの、機械出力はA点よりも大きくなる。
また、例えば、電力効率が最も高いピークは、機械出力のピークよりも負荷トルクがかなり低い位置にあるため、電力効率を優先させたい場合に、電力効率のピーク位置での制御を選択すると、充分な機械出力が得られないおそれがある。
一方、機械出力が最も高いピークは、電力効率のピークよりも負荷トルクがかなり大きい位置にあるため、機械出力を優先させたい場合に、機械出力のピーク位置での制御を選択すると、電力効率が大きく低下して、1本のバッテリ151では充分な作業時間が得られないおそれがある。
一方、機械出力が最も高いピークは、電力効率のピークよりも負荷トルクがかなり大きい位置にあるため、機械出力を優先させたい場合に、機械出力のピーク位置での制御を選択すると、電力効率が大きく低下して、1本のバッテリ151では充分な作業時間が得られないおそれがある。
このため、作業工具10の使用時には、使用者の求める性能(電力効率優位または機械出力優位)に応じて、適切なバランスでの設定が重要である。
よって、作業工具10の機械出力曲線と電力効率曲線とはピークとなる位置が一致しないため、設定に応じて、電力効率優位、あるいは機械出力優位を切り替えて、使用者にとって最適な設定にすることが好ましい。
よって、作業工具10の機械出力曲線と電力効率曲線とはピークとなる位置が一致しないため、設定に応じて、電力効率優位、あるいは機械出力優位を切り替えて、使用者にとって最適な設定にすることが好ましい。
本実施形態の作業工具10では、このように、作業工具10の機械出力曲線と電力効率曲線とをそれぞれ測定し、分離して出力・表示等することで、使用者に対して、作業工具10の性能を正確に把握させることができる。
よって、表示部22に表示された作業工具10の機械出力曲線と電力効率曲線とを確認した使用者等は、性能を把握した上でそのまま使用するか、あるいは、所望の性能になるように、制約条件を設定してフィードバック制御を実施することができる。
よって、表示部22に表示された作業工具10の機械出力曲線と電力効率曲線とを確認した使用者等は、性能を把握した上でそのまま使用するか、あるいは、所望の性能になるように、制約条件を設定してフィードバック制御を実施することができる。
また、現在の機械出力と電力効率とを参照した結果、作業工具10の性能を増強したい場合には、例えば、高効率の制御基板やモータに載せ替え(チューンアップ)することもできる。
ここで、実際にチューンアップした場合には、図3に示すグラフは、図4に示すように、ピーク値が上昇するように変化する。
ここで、実際にチューンアップした場合には、図3に示すグラフは、図4に示すように、ピーク値が上昇するように変化する。
すなわち、高効率の制御基板やモータへの載せ替え時には、電力効率のグラフが、実線から短い破線に変化することで、電力効率のピーク値を上昇させることができる。
また、機械出力が上昇するようなチューンアップを実施した場合には、機械効率のグラフが、長い破線から点線に変化することで、機械出力のピーク値を上昇させ、これに伴って、機械出力も上昇させることができる。
また、機械出力が上昇するようなチューンアップを実施した場合には、機械効率のグラフが、長い破線から点線に変化することで、機械出力のピーク値を上昇させ、これに伴って、機械出力も上昇させることができる。
また、図1に示す出力増加制御部134および出力増加機構115による作業工具10の出力増加について、図5を用いて説明すれば以下の通りである。
すなわち、作業工具10の出力を増加させる手段としては、図5に示すように、モータ制御による出力増加制御および機構的な手段が考えられる。
なお、図5に示す出力増加手段テーブルは、例えば、No1から順に優先的に選択されるものとし、上位にあるものから順に積み増し方式で採用されてもよい。
すなわち、作業工具10の出力を増加させる手段としては、図5に示すように、モータ制御による出力増加制御および機構的な手段が考えられる。
なお、図5に示す出力増加手段テーブルは、例えば、No1から順に優先的に選択されるものとし、上位にあるものから順に積み増し方式で採用されてもよい。
モータ制御による出力増加手段には、例えば、図5に示すように、進角制御(0~40度)、150度通電方式による制御等が考えられる。なお、進角制御および150度通電方式制御については、公知の制御であるから、ここでは詳細な説明を省略する。
これらの進角制御および150度通電方式制御は、図1に示す出力増加制御部134によって実施される。
これらの進角制御および150度通電方式制御は、図1に示す出力増加制御部134によって実施される。
進角制御は、モータの誘起電圧と巻線電流との位相合わせによって、トルクを最大限に引き出す制御であって、進角制御を実施した場合の出力増加量は、図5に示すように、約0~20%である。
150度通電方式制御は、3相ブラシレスモータの制御方法として採用される正弦波通電方式による制御であって、150度通電方式制御を実施した場合の出力増加量は、図5に示すように、約10%である。
150度通電方式制御は、3相ブラシレスモータの制御方法として採用される正弦波通電方式による制御であって、150度通電方式制御を実施した場合の出力増加量は、図5に示すように、約10%である。
また、機構的な出力増加手段には、例えば、図5に示すように、作業工具10がジグソーの場合のオービタル、あるいは、作業工具10が電動ドライバの場合のインパクトハンマ等が考えられる。
オービタルを組み合わせたジグソーの場合の出力増加量は、図5に示すように、段階的に選択可能なダイヤル操作によって、0,20,40,60%である。
オービタルを組み合わせたジグソーの場合の出力増加量は、図5に示すように、段階的に選択可能なダイヤル操作によって、0,20,40,60%である。
インパクトハンマを組み合わせた電動ドライバの場合の出力増加量は、図5に示すように、80%である。
本実施形態の作業工具10では、以上のように、外部端末20の表示部22に表示される機械出力曲線および電力効率曲線を参照した結果、使用者ごとに必要とする性能になるように、上述したチューンアップや制御面および機構面での出力増加手段を採用することによって、機械出力の増加、電力効率の向上を図ることができる。
なお、図5には示されていないが、制御面において作業工具10の機械出力を増加させる手段として、上述したPWM制御が採用されてもよい。
本実施形態の作業工具10では、以上のように、外部端末20の表示部22に表示される機械出力曲線および電力効率曲線を参照した結果、使用者ごとに必要とする性能になるように、上述したチューンアップや制御面および機構面での出力増加手段を採用することによって、機械出力の増加、電力効率の向上を図ることができる。
なお、図5には示されていないが、制御面において作業工具10の機械出力を増加させる手段として、上述したPWM制御が採用されてもよい。
<作業工具10への制約条件の設定処理>
本実施形態の作業工具10は、以上のような構成を備えており、図6に示すフローチャートに従って、トリガスイッチ121の操作から作業工具10の制御の制約条件の設定までの処理を実施する。
本実施形態の作業工具10は、以上のような構成を備えており、図6に示すフローチャートに従って、トリガスイッチ121の操作から作業工具10の制御の制約条件の設定までの処理を実施する。
なお、図6に示すフローチャートでは、ステップS11~S16,S17~S19は、作業工具10側の処理を示しており、ステップS21~S25は、外部端末20側の処理を示している。
すなわち、ステップS11では、使用者によってトリガスイッチ121が操作され、トリガスイッチ121が、OFF状態からON状態へ移行する。このとき、トリガスイッチ121の引き量(操作量)は、引き量センサ122aへ送信される。
すなわち、ステップS11では、使用者によってトリガスイッチ121が操作され、トリガスイッチ121が、OFF状態からON状態へ移行する。このとき、トリガスイッチ121の引き量(操作量)は、引き量センサ122aへ送信される。
次に、ステップS12では、ステップS11におけるトリガスイッチ121の引き量に応じてモータ111の回転が開始される。
なお、引き量センサ122aからの出力は、ログ出力部14を介してフィードバック制御部131へ送信される。そして、フィードバック制御部131は、設定された制約条件と、引き量センサ122aから出力されたトリガスイッチ121の引き量とに応じて、PWM出力をモータ駆動回路132へ送信する。これにより、モータ駆動回路132は、制約条件とトリガスイッチ121の引き量とに応じてモータ111の回転を制御することができる。
なお、引き量センサ122aからの出力は、ログ出力部14を介してフィードバック制御部131へ送信される。そして、フィードバック制御部131は、設定された制約条件と、引き量センサ122aから出力されたトリガスイッチ121の引き量とに応じて、PWM出力をモータ駆動回路132へ送信する。これにより、モータ駆動回路132は、制約条件とトリガスイッチ121の引き量とに応じてモータ111の回転を制御することができる。
次に、ステップS13では、制御部13の回転速度演算部133が、機構部11の位置検出部114からの信号を受信して、モータ111の回転速度の演算を開始する。
次に、ステップS14では、測定部16の機械出力曲線推定部161が、ステップS13において演算された回転速度と、モータ111のモータ電圧およびモータ電流とに基づいて、機械出力曲線の推定処理を実施する。
次に、ステップS14では、測定部16の機械出力曲線推定部161が、ステップS13において演算された回転速度と、モータ111のモータ電圧およびモータ電流とに基づいて、機械出力曲線の推定処理を実施する。
なお、測定部16の機械出力曲線推定部161における機械出力曲線の推定処理については、後段にて詳細に説明する。
次に、ステップS15では、測定部16の電力効率曲線推定部162が、ステップS14の機械出力曲線の推定処理の過程で算出された負荷トルクと、モータ電圧およびモータ電流と、電源部15のバッテリ151から出力されたバッテリ電圧およびバッテリ電流とに基づいて、電力効率曲線の推定処理を実施する。
次に、ステップS15では、測定部16の電力効率曲線推定部162が、ステップS14の機械出力曲線の推定処理の過程で算出された負荷トルクと、モータ電圧およびモータ電流と、電源部15のバッテリ151から出力されたバッテリ電圧およびバッテリ電流とに基づいて、電力効率曲線の推定処理を実施する。
なお、測定部16の電力効率曲線推定部162における電力効率曲線の推定処理については、後段にて詳細に説明する。
次に、ステップS16では、ログ出力部14が、測定部16から出力された機械出力曲線および電力効率曲線を受信して、外部端末20へ送信する。
次に、外部端末20側におけるステップS21では、作業工具10のログ出力部14から受信した機械出力曲線および電力効率曲線が、記憶部21へ書き込まれて保存される。
次に、ステップS16では、ログ出力部14が、測定部16から出力された機械出力曲線および電力効率曲線を受信して、外部端末20へ送信する。
次に、外部端末20側におけるステップS21では、作業工具10のログ出力部14から受信した機械出力曲線および電力効率曲線が、記憶部21へ書き込まれて保存される。
次に、ステップS22では、表示部22が、記憶部21に保存された機械出力曲線と電力効率曲線とを読み出して、表示画面に表示する(図3参照)。
次に、ステップS23では、使用者あるいは管理者によって、表示部22にすでに設定された制約条件等の設定条件の変更入力がされたか否かを判定する。ここで、入力があった場合には、ステップS24へ進み、入力がなかった場合には、変更なしとして処理を終了する。
次に、ステップS23では、使用者あるいは管理者によって、表示部22にすでに設定された制約条件等の設定条件の変更入力がされたか否かを判定する。ここで、入力があった場合には、ステップS24へ進み、入力がなかった場合には、変更なしとして処理を終了する。
次に、ステップS24では、設定部23が、使用者あるいは管理者から入力された機械出力曲線および電力効率曲線のバランス点から、新たな制約条件を生成する。
次に、ステップS25では、設定部23が、ステップS24において生成された新たな制約条件を、作業工具10側のフィードバック制御部131に対して送信する。
次に、作業工具10側のステップS17では、フィードバック制御部131が、外部端末20側の設定部23から受信した新たな制約条件を登録する。
次に、ステップS25では、設定部23が、ステップS24において生成された新たな制約条件を、作業工具10側のフィードバック制御部131に対して送信する。
次に、作業工具10側のステップS17では、フィードバック制御部131が、外部端末20側の設定部23から受信した新たな制約条件を登録する。
次に、ステップS18では、例えば、作業工具10側に設けられた表示画面等を用いて、制御面(進角制御、150度通電方式制御等)または機構面(オービタル、インパクトハンマ等)でのモータ111の出力増加設定を行うか否かを、使用者に確認する。ここで、使用者等が出力増加設定を行うことを希望する場合には、ステップS19において、所望の出力増加手段が選択され、処理を終了する。
なお、ステップS19において、制御面での出力増加手段が選択された場合には、出力増加制御部134によって出力増加制御(進角制御、150度通電方式制御等)が実施される。一方、機構面での出力増加手段が選択された場合には、例えば、使用者に対してオービタルの使用および段階を設定することを促す表示を行うように制御される。
なお、ステップS19において、制御面での出力増加手段が選択された場合には、出力増加制御部134によって出力増加制御(進角制御、150度通電方式制御等)が実施される。一方、機構面での出力増加手段が選択された場合には、例えば、使用者に対してオービタルの使用および段階を設定することを促す表示を行うように制御される。
<機械出力曲線の推定処理>
本実施形態の作業工具10は、図6のステップS14において、測定部16によって実施される機械出力曲線の推定処理を、図7のフローチャートに従って実施する。
本実施形態の作業工具10は、図6のステップS14において、測定部16によって実施される機械出力曲線の推定処理を、図7のフローチャートに従って実施する。
すなわち、ステップS31では、機械出力曲線推定部161の負荷トルク算出部161aが、入力されたモータ電圧・モータ電流に基づいて、負荷トルクを算出する。
次に、ステップS32では、機械出力算出部161bが、入力された回転速度と、算出された負荷トルクとに基づいて、実測値としての機械出力(第1機械出力)を算出する。
次に、ステップS33では、基準曲線取得部161dが、モータ特性記憶部161cに予め保存されたモータ特性のデータを読み出す。
次に、ステップS32では、機械出力算出部161bが、入力された回転速度と、算出された負荷トルクとに基づいて、実測値としての機械出力(第1機械出力)を算出する。
次に、ステップS33では、基準曲線取得部161dが、モータ特性記憶部161cに予め保存されたモータ特性のデータを読み出す。
次に、ステップS34では、基準曲線取得部161dが、読み出されたモータ特性に基づいて、機械出力基準曲線(基準機械出力)を作成する。
次に、ステップS35では、機械出力差分算出部161eが、負荷トルク、機械出力基準曲線(基準機械出力)、実測値としての機械出力(第1機械出力)を登録する。
次に、ステップS36では、機械出力差分算出部161eが、負荷トルクに対する機械出力基準曲線(基準機械出力)と実測値としての機械出力(第1機械出力)との差分を算出する。
次に、ステップS37では、曲線推定部161fが、ステップS36において算出された機械出力の差分を登録する。
次に、ステップS38では、曲線推定部161fが、機械出力の差分に補正倍率を掛けて、機械出力曲線を作成し、処理を終了する。
次に、ステップS35では、機械出力差分算出部161eが、負荷トルク、機械出力基準曲線(基準機械出力)、実測値としての機械出力(第1機械出力)を登録する。
次に、ステップS36では、機械出力差分算出部161eが、負荷トルクに対する機械出力基準曲線(基準機械出力)と実測値としての機械出力(第1機械出力)との差分を算出する。
次に、ステップS37では、曲線推定部161fが、ステップS36において算出された機械出力の差分を登録する。
次に、ステップS38では、曲線推定部161fが、機械出力の差分に補正倍率を掛けて、機械出力曲線を作成し、処理を終了する。
<電力供給曲線の推定処理>
本実施形態の作業工具10は、図6のステップS15において実施される電力効率曲線の推定処理を、図8のフローチャートに従って実施する。
本実施形態の作業工具10は、図6のステップS15において実施される電力効率曲線の推定処理を、図8のフローチャートに従って実施する。
すなわち、ステップ41では、入力電力算出部162bが、入力されたバッテリ電圧・バッテリ電流から、モータ111に入力される入力電圧を算出する。
次に、ステップS42では、出力電力算出部162aが、入力されたモータ電圧・モータ電流から、モータ111から出力された出力電力を算出する。
次に、ステップS43では、電力効率算出部162cが、機械出力曲線推定部161側の負荷トルク算出部161aから、負荷トルクを取得する。なお、このとき、電力効率算出部162cは、出力電力算出部162aおよび入力電力算出部162bから出力電力および入力電力をそれぞれ取得する。
次に、ステップS42では、出力電力算出部162aが、入力されたモータ電圧・モータ電流から、モータ111から出力された出力電力を算出する。
次に、ステップS43では、電力効率算出部162cが、機械出力曲線推定部161側の負荷トルク算出部161aから、負荷トルクを取得する。なお、このとき、電力効率算出部162cは、出力電力算出部162aおよび入力電力算出部162bから出力電力および入力電力をそれぞれ取得する。
次に、ステップS44では、電力効率算出部162cが、負荷トルク、入力電力および出力電力から、実測値としての電力効率(第1電力効率)を算出する。
次に、ステップS45では、基準曲線取得部162eが、モータ特性記憶部162dに予め保存されたモータ特性のデータを読み出す。
次に、ステップS46では、基準曲線取得部162eが、読み出されたモータ特性に基づいて、電力効率基準曲線(基準電力効率)を作成する。
次に、ステップS45では、基準曲線取得部162eが、モータ特性記憶部162dに予め保存されたモータ特性のデータを読み出す。
次に、ステップS46では、基準曲線取得部162eが、読み出されたモータ特性に基づいて、電力効率基準曲線(基準電力効率)を作成する。
次に、ステップS47では、電力効率差分算出部162fが、負荷トルク、電力効率基準曲線(基準電力効率)、実測値としての電力効率(第1電力効率)を登録する。
次に、ステップS48では、電力効率差分算出部162fが、負荷トルクに対する電力効率基準曲線(基準電力効率)と実測値としての電力効率(第1電力効率)との差分を算出する。
次に、ステップS49では、曲線推定部162gが、ステップS48において算出された電力効率の差分を登録する。
次に、ステップS50では、曲線推定部162gが、電力効率の差分に補正倍率を掛けて、電力効率曲線を作成し、処理を終了する。
次に、ステップS48では、電力効率差分算出部162fが、負荷トルクに対する電力効率基準曲線(基準電力効率)と実測値としての電力効率(第1電力効率)との差分を算出する。
次に、ステップS49では、曲線推定部162gが、ステップS48において算出された電力効率の差分を登録する。
次に、ステップS50では、曲線推定部162gが、電力効率の差分に補正倍率を掛けて、電力効率曲線を作成し、処理を終了する。
<フィードバック制御>
本実施形態の作業工具10は、以上のような構成を備えており、図9に示すフローチャートに従って、外部端末20側において設定あるいは変更された制約条件等に基づいて、作業工具10に搭載されたモータ111のフィードバック制御を実施する。
本実施形態の作業工具10は、以上のような構成を備えており、図9に示すフローチャートに従って、外部端末20側において設定あるいは変更された制約条件等に基づいて、作業工具10に搭載されたモータ111のフィードバック制御を実施する。
すなわち、ステップ51では、フィードバック制御部131が、外部端末20から受信した制約条件を確認する。
次に、ステップS52では、フィードバック制御部131が、ステップS51において受信した制約条件に基づいて、モータ出力の増加の必要量を算出する。
次に、ステップS53では、フィードバック制御部131が、ステップS52において算出した出力増加設定を満たすように出力増加手段テーブル(図5参照)を参照し、出力増加手段を選択する。
次に、ステップS52では、フィードバック制御部131が、ステップS51において受信した制約条件に基づいて、モータ出力の増加の必要量を算出する。
次に、ステップS53では、フィードバック制御部131が、ステップS52において算出した出力増加設定を満たすように出力増加手段テーブル(図5参照)を参照し、出力増加手段を選択する。
ここで、出力増加設定とは、選択される出力増加手段と設定(強度またはON/OFF)とをまとめた情報である。
なお、図5に示す出力増加手段テーブルから出力増加手段を選択する処理は、作業工具10の制御部13において実施されてもよいし、使用者等に出力増加手段テーブルを提示して選択するように促してもよい。
なお、図5に示す出力増加手段テーブルから出力増加手段を選択する処理は、作業工具10の制御部13において実施されてもよいし、使用者等に出力増加手段テーブルを提示して選択するように促してもよい。
次に、ステップS54では、フィードバック制御部131は、ステップS53における選択結果に応じて、出力増加設定を実施するように、出力増加制御部134および出力増加機構115へ送信する。
次に、ステップS55では、出力増加制御部134が、フィードバック制御部131から受信した出力増加設定に基づいて、出力増加制御(進角制御、150度通電方式制御等)を実施する。
次に、ステップS56では、出力増加機構115が、フィードバック制御部131から受信した出力増加設定に基づいて、出力増加手段(オービタル、インパクトハンマ等)を用いた作業を実施する。
次に、ステップS55では、出力増加制御部134が、フィードバック制御部131から受信した出力増加設定に基づいて、出力増加制御(進角制御、150度通電方式制御等)を実施する。
次に、ステップS56では、出力増加機構115が、フィードバック制御部131から受信した出力増加設定に基づいて、出力増加手段(オービタル、インパクトハンマ等)を用いた作業を実施する。
<ジグソー50を用いた場合の出力増加機構>
本実施形態の作業工具10として、図10に示すジグソー50を用いた場合の出力増加機構の一例について、以下で説明する。
本実施形態の作業工具10として、図10に示すジグソー50を用いた場合の出力増加機構の一例について、以下で説明する。
ジグソー50は、鋸刃52を高速で上下方向に往復移動させることで、木材や金属を切削する作業工具であって、図10に示すように、本体部51と、鋸刃52と、オービタル(出力増加機構)53とを備えている。
なお、鋸刃52の上下方向における往復移動とは、図11における上下方向であって、本体部51に対して進退する方向における往復移動を意味している。
なお、鋸刃52の上下方向における往復移動とは、図11における上下方向であって、本体部51に対して進退する方向における往復移動を意味している。
本体部51は、内部に、図1に示す構成(例えば、モータ111、バッテリ151等)を内蔵しており、トリガスイッチ121の引き量に応じた速度でモータ111が回転することで、鋸刃52を上下に往復移動させる。
鋸刃52は、機構部11の先端に装着された先端工具であって、本体部51から下向きに突出するように取り付けられている。
鋸刃52は、機構部11の先端に装着された先端工具であって、本体部51から下向きに突出するように取り付けられている。
オービタル53は、図11に示すように、鋸刃52の本体部51への取付部分に近接する鋸刃52の根元部分に当接配置されている。そして、オービタル53は、鋸刃52の上下方向における往復移動時に、図11に示す側面視において、鋸刃52の先端部分が楕円軌道上を移動するように、鋸刃52を刃がある方向へ段階的に押し出す機構である。
なお、オービタル53による鋸刃52の押し付け量は、例えば、4段階で設定されるように構成されている。段階的な設定は、図示しない切替駆動部(モータ、ソレノイド等)によって実施される。
なお、オービタル53による鋸刃52の押し付け量は、例えば、4段階で設定されるように構成されている。段階的な設定は、図示しない切替駆動部(モータ、ソレノイド等)によって実施される。
これにより、ジグソー50によって切削を行う材料の硬さ、作業速度等を考慮して、オービタル53の設定を段階的に切り替えて作業を実施することができる。
ここで、例えば、図12(a)に示す金属板M1を1枚切削する場合と、図12(b)に示す金属板M1,M2を2枚切削する場合とでは、金属板の厚さが2倍になることで、作業工具10のモータ111に掛かるモータ負荷電流(負荷トルク)も2倍になる。
ここで、例えば、図12(a)に示す金属板M1を1枚切削する場合と、図12(b)に示す金属板M1,M2を2枚切削する場合とでは、金属板の厚さが2倍になることで、作業工具10のモータ111に掛かるモータ負荷電流(負荷トルク)も2倍になる。
同様に、例えば、図13(a)に示す木板W1を1枚切削する場合と、図13(b)に示す木板W1,W2を2枚切削する場合とでは、木板の厚さが2倍になることで、作業工具10のモータ111に掛かるモータ負荷電流(負荷トルク)も2倍になる。
さらに、上述したジグソー50のオービタル53を使用した場合には、切削作業の作業時間は短縮される一方で、切削対象となる材料の厚みの増加と同様に、負荷電流(負荷トルク)が増加する。
さらに、上述したジグソー50のオービタル53を使用した場合には、切削作業の作業時間は短縮される一方で、切削対象となる材料の厚みの増加と同様に、負荷電流(負荷トルク)が増加する。
本実施形態の作業工具10では、以上のような構成により、機械出力曲線と電力効率曲線とをそれぞれ独立して測定し、出力・表示等されることで、使用者によって必要な性能の有無を正確に判定することができる。
そして、機械出力曲線を見て、出力を増加させたい場合には、上述した出力増加制御や、出力増加機構を活用して、機械出力を増加させた作業工具10を得ることができる。
そして、機械出力曲線を見て、出力を増加させたい場合には、上述した出力増加制御や、出力増加機構を活用して、機械出力を増加させた作業工具10を得ることができる。
さらに、使用者は、同一の機械出力点において電力効率の高低を比較することができるため、より効率の高い製品を購入できる、もしくは高効率な制御基板やモータを購入しての載せ替え(チューンナップ)を検討することができる。
また、機械出力の上昇による作業効率上昇と、電力効率の低下によるバッテリの持ち低下の寄与率(%)を容易に判断することができるため、バッテリ1本あたりの、作業効率(=1回の作業にかかる時間)とバッテリの持ち(=残りの回数)を、使用者ごとの作業における適正値に設定して、より正確な作業計画を立てることができる。
また、機械出力の上昇による作業効率上昇と、電力効率の低下によるバッテリの持ち低下の寄与率(%)を容易に判断することができるため、バッテリ1本あたりの、作業効率(=1回の作業にかかる時間)とバッテリの持ち(=残りの回数)を、使用者ごとの作業における適正値に設定して、より正確な作業計画を立てることができる。
[他の実施形態]
以上、本発明の一実施形態について説明したが、本発明は上記実施形態に限定されるものではなく、発明の要旨を逸脱しない範囲で種々の変更が可能である。
(A)
上記実施形態では、作業工具10側において算出された機械出力および電力効率を、ログ出力部14から、PC(Personal Computer)、タブレット端末、スマートフォン等の外部端末20に対して送信し、外部端末20の表示部22において表示させる例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
以上、本発明の一実施形態について説明したが、本発明は上記実施形態に限定されるものではなく、発明の要旨を逸脱しない範囲で種々の変更が可能である。
(A)
上記実施形態では、作業工具10側において算出された機械出力および電力効率を、ログ出力部14から、PC(Personal Computer)、タブレット端末、スマートフォン等の外部端末20に対して送信し、外部端末20の表示部22において表示させる例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、図14に示すように、作業工具210が表示部222(例えば、液晶タッチパネル等)を備えている構成であれば、作業工具210側の表示部222において、機械出力や電力効率を表示させるような構成であってもよい。このとき、機械出力および電力効率を外部へ出力する出力部の構成を削除してもよい。
この場合でも、作業工具の使用者あるいは管理者等は、表示部に表示された機械出力および電力効率を確認して、作業工具の性能を正確に把握することができるとともに、必要に応じて、所望の性能になるように調整することができるという、上記と同様の効果を得ることができる。
この場合でも、作業工具の使用者あるいは管理者等は、表示部に表示された機械出力および電力効率を確認して、作業工具の性能を正確に把握することができるとともに、必要に応じて、所望の性能になるように調整することができるという、上記と同様の効果を得ることができる。
(B)
上記実施形態では、機械出力曲線および電力効率曲線を出力・表示して、機械出力と電力効率のバランス点の変更、モータ111の制約条件の見直し等を行う例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、バッテリ残量推定部を備えた作業工具である場合には、機械出力と電力効率とのバランス点ごとに消費される電力を算出することで、残りの作業可能時間を推定することができるという効果も奏することができる。
上記実施形態では、機械出力曲線および電力効率曲線を出力・表示して、機械出力と電力効率のバランス点の変更、モータ111の制約条件の見直し等を行う例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、バッテリ残量推定部を備えた作業工具である場合には、機械出力と電力効率とのバランス点ごとに消費される電力を算出することで、残りの作業可能時間を推定することができるという効果も奏することができる。
(C)
上記実施形態では、電力効率曲線推定部162において電力効率を算出する際に必要な負荷トルクを、機械出力曲線推定部161側から取得する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、電力効率曲線推定部において、直接、入力されたモータ電圧・モータ電流を用いて負荷トルクを算出し、これを用いて電力効率を算出してもよい。
上記実施形態では、電力効率曲線推定部162において電力効率を算出する際に必要な負荷トルクを、機械出力曲線推定部161側から取得する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、電力効率曲線推定部において、直接、入力されたモータ電圧・モータ電流を用いて負荷トルクを算出し、これを用いて電力効率を算出してもよい。
(D)
上記実施形態では、機械出力曲線推定部161が、機械出力算出部161bにおいて算出された機械出力の値を、モータ特性記憶部161cに記憶された基準機械出力と比較して補正して、精度の高い機械出力を出力・表示する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、機械出力算出部において算出された機械出力の値を、そのまま最終的な機械出力として出力・表示等してもよい。
上記実施形態では、機械出力曲線推定部161が、機械出力算出部161bにおいて算出された機械出力の値を、モータ特性記憶部161cに記憶された基準機械出力と比較して補正して、精度の高い機械出力を出力・表示する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、機械出力算出部において算出された機械出力の値を、そのまま最終的な機械出力として出力・表示等してもよい。
(E)
上記実施形態では、電力効率曲線推定部162が、電力効率算出部162cにおいて算出された電力効率の値を、モータ特性記憶部162dに記憶された基準電力効率と比較して補正して、精度の高い電力効率を出力・表示する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、電力効率算出部において算出された電力効率の値を、そのまま最終的な電力効率として出力・表示等してもよい。
上記実施形態では、電力効率曲線推定部162が、電力効率算出部162cにおいて算出された電力効率の値を、モータ特性記憶部162dに記憶された基準電力効率と比較して補正して、精度の高い電力効率を出力・表示する例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、電力効率算出部において算出された電力効率の値を、そのまま最終的な電力効率として出力・表示等してもよい。
(F)
上記実施形態では、本発明の制御システム100を構成する外部端末20として、作業工具10と通信可能なPC(Personal Computer)を用いた例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、PC以外に、スマートフォンやタブレット端末等のように、表示機能と設定機能とを備えた外部端末であってもよい。
上記実施形態では、本発明の制御システム100を構成する外部端末20として、作業工具10と通信可能なPC(Personal Computer)を用いた例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、PC以外に、スマートフォンやタブレット端末等のように、表示機能と設定機能とを備えた外部端末であってもよい。
(G)
上記実施形態では、交換可能なバッテリ151から電力供給を受けて駆動される作業工具10に対して、本発明を適用した例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、コード式の作業工具に対して、本発明を適用してもよい。
この場合でも、例えば、電力効率が高い(電力消費量が小さい)作業工具、あるいは機械出力が大きい作業工具、を選択することで、使用者ごとに最適な作業工具を提供することができる。
上記実施形態では、交換可能なバッテリ151から電力供給を受けて駆動される作業工具10に対して、本発明を適用した例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、コード式の作業工具に対して、本発明を適用してもよい。
この場合でも、例えば、電力効率が高い(電力消費量が小さい)作業工具、あるいは機械出力が大きい作業工具、を選択することで、使用者ごとに最適な作業工具を提供することができる。
(H)
上記実施形態では、電力消費体に搭載されたモータとして、3相DCブラシレスモータを用いた例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、制御対象として、ブラシ付きDCモータ等の他のモータを備えた電力消費体であってもよい。
上記実施形態では、電力消費体に搭載されたモータとして、3相DCブラシレスモータを用いた例を挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、制御対象として、ブラシ付きDCモータ等の他のモータを備えた電力消費体であってもよい。
(I)
上記実施形態では、本発明の作業工具として、ジグソー50を例として挙げて説明した。しかし、本発明はこれに限定されるものではない。
上記実施形態では、本発明の作業工具として、ジグソー50を例として挙げて説明した。しかし、本発明はこれに限定されるものではない。
例えば、ジグソー以外では、電動ドライバ、チェーンソー等、他の作業工具に対して、本発明を適用してもよい。
本発明の作業工具は、使用者にとって最適な作業工具を提供することができるという効果を奏することから、モータを搭載した各種作業工具に対して広く適用可能である。
10 作業工具
11 機構部
12 入力部
13 制御部
14 ログ出力部(出力部)
15 電源部
16 測定部
20 外部端末
21 記憶部
22 表示部
23 設定部
50 ジグソー(作業工具)
51 本体部
52 鋸刃
53 オービタル(出力増加機構)
100 制御システム
111 モータ
112 減速機
113 出力部
114 位置検出部
115 出力増加機構(機械出力増加機構)
121 トリガスイッチ
122 センサ回路
122a 引き量センサ
122b 電圧センサ
122c 電流センサ
122d トルクセンサ
122e 温度センサ
131 フィードバック制御部
132 モータ駆動回路
133 回転速度演算部
134 出力増加制御部
151 バッテリ
152 バッテリ制御部
161 機械出力曲線推定部(機械出力測定部)
161a 負荷トルク算出部
161b 機械出力算出部(第1算出部)
161c モータ特性記憶部
161d 基準曲線取得部
161e 機械出力差分算出部
161f 曲線推定部(第1補正部)
162 電力効率曲線推定部(電力効率測定部)
162a 出力電力算出部
162b 入力電力算出部
162c 電力効率算出部(第2算出部)
162d モータ特性記憶部
162e 基準曲線取得部
162f 電力効率差分算出部
162g 曲線推定部(第2補正部)
210 作業工具
222 表示部
M1,M2 金属板
W1,W2 木板
11 機構部
12 入力部
13 制御部
14 ログ出力部(出力部)
15 電源部
16 測定部
20 外部端末
21 記憶部
22 表示部
23 設定部
50 ジグソー(作業工具)
51 本体部
52 鋸刃
53 オービタル(出力増加機構)
100 制御システム
111 モータ
112 減速機
113 出力部
114 位置検出部
115 出力増加機構(機械出力増加機構)
121 トリガスイッチ
122 センサ回路
122a 引き量センサ
122b 電圧センサ
122c 電流センサ
122d トルクセンサ
122e 温度センサ
131 フィードバック制御部
132 モータ駆動回路
133 回転速度演算部
134 出力増加制御部
151 バッテリ
152 バッテリ制御部
161 機械出力曲線推定部(機械出力測定部)
161a 負荷トルク算出部
161b 機械出力算出部(第1算出部)
161c モータ特性記憶部
161d 基準曲線取得部
161e 機械出力差分算出部
161f 曲線推定部(第1補正部)
162 電力効率曲線推定部(電力効率測定部)
162a 出力電力算出部
162b 入力電力算出部
162c 電力効率算出部(第2算出部)
162d モータ特性記憶部
162e 基準曲線取得部
162f 電力効率差分算出部
162g 曲線推定部(第2補正部)
210 作業工具
222 表示部
M1,M2 金属板
W1,W2 木板
Claims (16)
- モータと、
使用者によって操作され、操作量に応じて前記モータの出力を調整するトリガスイッチと、
前記トリガスイッチが操作されて回転した前記モータの負荷トルクに対する機械出力を測定する機械出力測定部と、
前記トリガスイッチが操作されて回転した前記モータの負荷トルクに対する電力効率を測定する電力効率測定部と、
を備えている作業工具。 - 前記機械出力測定部において測定された機械出力と、前記電力効率測定部において測定された電力効率と、をそれぞれ表示する表示部を、さらに備えている、
請求項1に記載の作業工具。 - 前記機械出力測定部において測定された機械出力と、前記電力効率測定部において測定された電力効率とを、外部へ出力する出力部を、さらに備えている、
請求項1または2に記載の作業工具。 - 前記機械出力測定部は、前記モータに流れるモータ電流から前記モータの負荷トルクを算出する負荷トルク算出部と、前記負荷トルク算出部において算出された前記負荷トルクと前記モータの回転速度とに基づいて第1機械出力を算出する第1算出部と、を有している、
請求項1から3のいずれか1項に記載の作業工具。 - 前記機械出力測定部は、前記第1算出部において算出された第1機械出力と、前記モータの機械出力の基準となる基準機械出力とを比較して、前記第1機械出力と前記基準機械出力との差分に基づいて、前記第1機械出力を補正する第1補正部を、さらに有している、
請求項4に記載の作業工具。 - 前記電力効率測定部は、前記モータに入力される入力電力と前記モータから出力された出力電力と、前記モータの負荷トルクとに基づいて、第1電力効率を算出する第2算出部を、有している、
請求項1から5のいずれか1項に記載の作業工具。 - 前記電力効率測定部は、前記第2算出部において算出された第1電力効率と、前記モータの電力効率の基準となる基準電力効率とを比較して、前記第1電力効率と前記基準電力効率との差分に基づいて、前記第1電力効率を補正する第2補正部を、さらに有している、
請求項6に記載の作業工具。 - 前記モータの出力を増加させる出力増加制御部を、さらに備えている、
請求項1から7のいずれか1項に記載の作業工具。 - 前記出力増加制御部は、PWM(Pulse Width Modulation)制御、進角制御、150度通電方式制御のうちの少なくとも1つを実施する、
請求項8に記載の作業工具。 - 前記機械出力を増加させる機械出力増加機構を、さらに備えている、
請求項1から9のいずれか1項に記載の作業工具。 - 前記機械出力増加機構は、オービタルあるいはインパクトハンマである、
請求項10に記載の作業工具。 - 前記機械出力および前記電力効率に基づいて設定された制約条件のもとで、フィードバック制御を行うフィードバック制御部を、さらに備えている、
請求項1から11のいずれか1項に記載の作業工具。 - 前記モータの制御に関する値を検出するセンサを、さらに備えている、
請求項1から12のいずれか1項に記載の作業工具。 - 前記センサは、前記トリガスイッチの操作量を検出するセンサ、前記モータに印加される電圧を検出する電圧センサ、前記モータに流れる電流を検出する電流センサ、前記モータの温度を検出する温度センサを含む、
請求項13に記載の作業工具。 - 前記モータは、ブラシレスモータである、
請求項1から14のいずれか1項に記載の作業工具。 - 請求項1から15のいずれか1項に記載の作業工具と、
前記機械出力および前記電力効率を保存する記憶部と、前記機械出力および前記電力効率に基づく情報を表示する表示部と、を有する外部端末と、
を備えた制御システム。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019061588A JP2020157444A (ja) | 2019-03-27 | 2019-03-27 | 作業工具およびこれを備えた制御システム |
| JP2019-061588 | 2019-03-27 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020195321A1 true WO2020195321A1 (ja) | 2020-10-01 |
Family
ID=72611816
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/006021 Ceased WO2020195321A1 (ja) | 2019-03-27 | 2020-02-17 | 作業工具およびこれを備えた制御システム |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP2020157444A (ja) |
| WO (1) | WO2020195321A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025121402A1 (ja) * | 2023-12-07 | 2025-06-12 | 株式会社村田製作所 | 回転電機 |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7593195B2 (ja) * | 2021-03-29 | 2024-12-03 | トヨタ自動車株式会社 | モータ劣化推定方法及びモータ劣化推定装置 |
Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2012165113A1 (ja) * | 2011-06-02 | 2012-12-06 | 株式会社マキタ | 動力工具 |
-
2019
- 2019-03-27 JP JP2019061588A patent/JP2020157444A/ja active Pending
-
2020
- 2020-02-17 WO PCT/JP2020/006021 patent/WO2020195321A1/ja not_active Ceased
Patent Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2012165113A1 (ja) * | 2011-06-02 | 2012-12-06 | 株式会社マキタ | 動力工具 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025121402A1 (ja) * | 2023-12-07 | 2025-06-12 | 株式会社村田製作所 | 回転電機 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP2020157444A (ja) | 2020-10-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| WO2020195323A1 (ja) | 作業工具およびこれを備えた制御システム | |
| CN200988190Y (zh) | 旋转冲击动力工具 | |
| US11701759B2 (en) | Electric power tool | |
| CN106998168B (zh) | 电动工作机 | |
| US11806855B2 (en) | Electric power tool, and method for controlling motor of electric power tool | |
| JP2020157444A (ja) | 作業工具およびこれを備えた制御システム | |
| US11247323B2 (en) | Electric working machine and method of controlling rotational state of motor of electric working machine | |
| US11235453B2 (en) | Electric working machine and method of controlling rotational state of motor of electric working machine | |
| US20170222582A1 (en) | Electric working machine and method for detecting rotational position of rotor of brushless motor for electric working machine | |
| CA2941582A1 (en) | Programmable portable power tool with brushless dc motor | |
| JP2007518582A (ja) | 作業領域が最適化される手持ち式電動工具 | |
| RU2011101641A (ru) | Аккумуляторная ручная машина и способ управления работой аккумуляторной ручной машины | |
| TW201406506A (zh) | 衝擊式電動工具之衝擊作動控制方法及其裝置 | |
| CN111788053A (zh) | 用于电动工具的模拟停滞系统和方法 | |
| WO2020195322A1 (ja) | 作業工具およびこれを備えた制御システム | |
| JP2009083042A (ja) | 電池電源型電動工具 | |
| US12358114B2 (en) | Method for operating a hand-held machine tool, and hand-held machine tool | |
| US10998805B2 (en) | Power tool with direction sensing controller | |
| JP2003311653A (ja) | 電動工具 | |
| US10065297B2 (en) | Method and device for operating a hand-held machine tool with a tangential impact mechanism | |
| JP6489346B2 (ja) | 電動工具 | |
| JP2019188568A (ja) | 電力消費体の制御装置、制御システム、および電力消費体の制御方法 | |
| JP2020517471A (ja) | 電気パルス工具 | |
| JP2013523501A (ja) | ステープルカートリッジ | |
| JP2015530933A (ja) | 手持ち式電動工具の電動モータ制御方法及び電動モータ制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20776863 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20776863 Country of ref document: EP Kind code of ref document: A1 |