WO2020175179A1 - ブレーキシステム、ブレーキ制御装置、ブレーキ制御方法およびブレーキ制御プログラム - Google Patents
ブレーキシステム、ブレーキ制御装置、ブレーキ制御方法およびブレーキ制御プログラム Download PDFInfo
- Publication number
- WO2020175179A1 WO2020175179A1 PCT/JP2020/005742 JP2020005742W WO2020175179A1 WO 2020175179 A1 WO2020175179 A1 WO 2020175179A1 JP 2020005742 W JP2020005742 W JP 2020005742W WO 2020175179 A1 WO2020175179 A1 WO 2020175179A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- hydraulic pressure
- electric motor
- brake
- power supply
- holding
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T13/00—Transmitting braking action from initiating means to ultimate brake actuator with power assistance or drive; Brake systems incorporating such transmitting means, e.g. air-pressure brake systems
- B60T13/74—Transmitting braking action from initiating means to ultimate brake actuator with power assistance or drive; Brake systems incorporating such transmitting means, e.g. air-pressure brake systems with electrical assistance or drive
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T7/00—Brake-action initiating means
- B60T7/12—Brake-action initiating means for automatic initiation; for initiation not subject to will of driver or passenger
Definitions
- Shake _ ⁇ The system blur _ key control unit, the blur _ key control method and blur _ key control program
- the present invention relates to a brake system that applies a braking force to a vehicle such as an automobile, a brake control device, a brake control method, and a brake control program.
- a brake system that applies a braking force to a vehicle such as an automobile by supplying hydraulic pressure (brake hydraulic pressure) to a hydraulic brake (hydraulic braking device) on each wheel side.
- hydraulic pressure brake hydraulic pressure
- hydraulic brake hydraulic brake
- the hydraulic brake is a disk brake, for example, by supplying hydraulic pressure from the outside into the cylinder of the caliber, the brake pad (braking member) is transferred to the disk rotor (member to be braked) via the piston. Press to generate braking force.
- a disc brake for example, not only a braking force is generated based on hydraulic pressure when the vehicle is running, but also an electric motor (electric motor) is driven when the vehicle is stopped or parked, or when traveling as necessary.
- An electric motor electric motor
- a hydraulic disc brake with an electric parking brake function that generates a braking force based on (rotation) is known (Patent Document 1).
- Patent Document 1 Japanese Patent Laid-Open No. 20 15-47 9 45 (Japanese Patent No. 6227333)
- the thrust may become excessive (excessive).
- An object of the present invention is to apply an excessive thrust force when a vehicle state changes (for example, a change in hydraulic pressure) when applying (that is, when a braking force is maintained based on driving of an electric motor). It is to provide a brake system, a brake control device, a brake control method, and a brake control program capable of suppressing a shortage.
- a brake system mounted on a vehicle includes a hydraulic braking device that propels a piston by hydraulic pressure to press a braking member against a braked member, and a thrust force transmitted from an electric motor.
- An electric brake device that pushes the braking member against the braked member by propelling the piston to hold the braking force, and an electric power to the electric motor in the section where the thrust is generated in the viston when the braking force is held.
- a control device that restarts the power supply to the electric motor after the power supply is temporarily stopped, and that completes the holding of the braking force when a holding completion condition that completes the holding of the braking force is satisfied;
- the control device determines the holding completion condition based on a change in the vehicle state of the vehicle when the power supply is temporarily stopped.
- the brake control device mounted on the vehicle is characterized in that the brake mechanism for pushing the braking member against the braked member by propelling the piston by the hydraulic pressure or the thrust transmitted from the electric motor.
- a control unit for controlling the electric motor wherein the control unit drives the electric motor in response to a control command for holding the braking force of the brake mechanism, and when the electric current in which the thrust is generated in the piston is increased, , After temporarily stopping the electric power supply to the electric motor, restarting the electric power supply to the electric motor, and when the holding completion condition for completing the holding of the braking force is satisfied, the holding of the braking force is completed, When the power supply to the electric motor is temporarily stopped, the holding completion condition is determined based on the change in the vehicle state of the vehicle.
- a brake control method is a hydraulic or electric motor. ⁇ 2020/175179 3 (:171? 2020/005742
- a method of controlling the electric motor in a brake mechanism for propelling a piston by a thrust force transmitted from a vehicle to press a braking member against a member to be braked comprising: A step of starting the current supply to the electric motor; a step of temporarily stopping the electric power supply to the electric motor when the electric current increases while thrust is being generated in the piston; and a step of supplying the electric power to the electric motor.
- the step of setting a holding completion condition for completing the holding of the braking force based on the change in the vehicle state of the vehicle equipped with the brake mechanism, and the power supply to the electric motor includes the steps of resuming the power supply to the electric motor after being temporarily stopped, and the step of completing the holding of the braking force when the holding completion condition is satisfied.
- a brake control program controls the electric motor in a brake mechanism that propels a piston by a hydraulic pressure or a thrust force transmitted from the electric motor to press a braking member against a braked member.
- a program to be executed by the brake control device the step of starting current supply to the electric motor in response to a control command for holding the braking force of the brake mechanism, and a current increase in which thrust is generated in the piston.
- the thrust force is changed according to the change of the vehicle state (for example, the fluctuation of the hydraulic pressure). It is possible to suppress excess or shortage.
- FIG. 1 A conceptual view of a vehicle equipped with a brake system according to a first embodiment.
- FIG. 2 Disc with electric parking brake function provided on the rear wheel side in Fig. 1. ⁇ 2020/175 179 4 ⁇ (:171? 2020 /005742
- Fig. 3 is a block diagram showing the parking brake control device in Fig. 1 together with a rear wheel side disc brake and the like.
- FIG. 4 A flow chart showing a control process by the parking brake control device in Fig. 1.
- FIG. 5 Flow chart showing the process following "8" and "Mimi" in Fig. 4.
- FIG. 6 A flow chart showing the " ⁇ ? Judgment process" of 39 in Fig. 5.
- FIG. 7 A characteristic diagram showing an example of the relationship between the hydraulic pressure and the threshold current for applying stop current I 8 3 ⁇ .
- FIG. 8 Change in hydraulic pressure ⁇ and re-energization time 1
- the characteristic diagram which shows an example of the relationship with.
- FIG. 9 A characteristic diagram showing an example of temporal changes in the motor current and the hydraulic pressure according to the first embodiment.
- FIG. 10 A flow chart showing a control process (process following “8” and “Mimi” in FIG. 4) according to the second embodiment.
- FIG. 11 A flowchart showing the " ⁇ ? Judgment process" of 3 2 1 in Fig. 10.
- FIG. 12 A characteristic diagram showing an example of temporal changes in motor current I and hydraulic pressure according to the second embodiment.
- FIG. 13 An explanatory view (characteristic diagram of time change) showing a hydraulic pressure error due to a delay in the control recognition value with respect to the true value of the carrier hydraulic pressure.
- FIGS. 1 to 9 show a first embodiment.
- Fig. 1 for example, the left and right front wheels 2 (!_
- the vehicle braking system will be described below.
- the front wheel 2 and the rear wheel 3 are provided with a disc rotor 4 as a braked member (rotating member) that rotates together with each wheel (each front wheel 2, each rear wheel 3).
- the disc rotor 4 for the front wheels 2 is applied with a braking force by a front disc brake 5 which is a hydraulic disc brake.
- the disc wheel 4 for the rear wheel 3 is provided with braking force by the disc brake 6 on the rear wheel side, which is a hydraulic disc brake with an electric parking brake function.
- a pair (one set) of the rear wheel-side disk brakes 6 provided corresponding to the left and right rear wheels 3 are provided with a brake pad 60 (see FIG. 2) which is hydraulically applied to the disc brake 4 at a time. It is a hydraulic brake mechanism that applies a braking force by pressing.
- the rear wheel side disc brake 6 includes, for example, a mounting member 6 called a carrier, a caliber 6M as a wheel cylinder, and a pair of brakes as a braking member (a friction member, a friction pad).
- the pad 6 (3 and the piston 60 as a pressing member are provided.
- the caliper 6 and the piston 60 are hydraulically propelled by the piston 6 0 to disc the brake pad 60. It forms a cylinder mechanism (hydraulic braking device) that presses against the rotor 4.
- the mounting member 6 is fixed to a non-rotating portion of the vehicle and is formed so as to straddle the outer peripheral side of the disc rotor 4.
- the caliper 6 is provided on the mounting member 68 so that the disc rotor 4 can move in the axial direction.
- the caliber 6M is composed of a cylinder main body 6M 1, a claw 6M 2 and a bridge 6M 3 connecting them.
- the cylinder body 6 6 1 is provided with a cylinder (cylinder hole) 6 6 and the piston 6 0 is fitted in the cylinder 6 4.
- the brake pad 60 is movably mounted on the mounting member 68, and is arranged so as to be able to abut the disk rotor 4.
- the piston 60 presses the brake pad 60 against the disc rotor 4.
- the caliber 6 is the cylinder based on the operation of the brake pedal 9 or the like.
- the brake pad 60 By supplying (adding) the hydraulic pressure (brake hydraulic pressure) into the 6x4, the brake pad 60 is propelled by the piston 60. At this time, the brake pad 60 ⁇ 2020/175 179 6 ⁇ (:171? 2020 /005742
- the rear wheel side disc brake 6 includes an electric actuator 7 and a rotary/linear motion mechanism 8.
- the electric actuator 7 includes an electric motor 7 as an electric motor, a speed reducer (not shown) for reducing the rotation of the electric motor 7, and the like.
- the electric motor 78 serves as a propulsion source (drive source) for propelling the piston 60.
- the rotation/linear motion mechanism 8 constitutes a holding mechanism (pressing member holding mechanism) that holds the pressing force of the brake pad 60.
- the rotation/linear motion mechanism 8 converts the rotation of the electric motor 78 into a displacement in the axial direction of the piston 60 (linear motion displacement) and at the same time drives the rotation linear motion member 8 for propelling the piston 60.
- the rotary direct-acting member 8 is composed of, for example, a screw member 8 1 made of a rod-shaped body having a male screw and a direct-acting member 8 2 having a female screw hole formed on the inner peripheral side as a propelling member. ..
- the rotation/linear motion mechanism 8 converts the rotation of the electric motor 78 into the axial displacement of the 6 viston, and also holds the piston 60 propelled by the electric motor 78. That is, the rotary direct drive mechanism 8 applies thrust to the piston 60 by the electric motor 78, propels the brake pad 60 by the piston 60 to press the disc rotor 4, and thrust of the piston 6 mouth. Hold.
- the rear wheel side disc brake 6 is provided with the rotary/linear motion mechanism 8 and the electric motor 78.
- the rotation/linear motion mechanism 8 and the electric motor 78 form an electric brake mechanism (electric brake device).
- the electric brake mechanism converts the rotational force of the electric motor 7 into thrust through the speed reducer and the rotary linear motion mechanism 8, and applies the thrust to the piston 60 that presses the brake pad 6 (3 to reduce the braking force.
- the electric brake mechanism is driven by the rotation/linear motion mechanism 8 driven by the electric motor 78, and the Biston 60 pushes the brake pad 60 against the disc rotor 4 to drive the electric motor. Hold the brake pad 60 at the pressing position by stopping 7 ⁇ 2020/175 179 7 ⁇ (:171? 2020/005742
- the rotary/linear motion mechanism 8 and the electric motor 78 that form the electric brake mechanism include a caliber 6 and a piston 60 that form a cylinder mechanism (hydraulic braking device), and a parking brake described later. Together with the control unit 24, it constitutes a braking system.
- the electric brake mechanism (electric brake device) propels the piston 60 by the thrust transmitted from the electric motor 78 and presses the brake pad 6 (3) against the disc rotor 4 to hold the braking force.
- the rear wheel side disc brake 6 propels the piston 60 with the brake fluid pressure generated based on the operation of the brake pedal 9 and the like, and presses the disc rotor 4 with the brake pad 60, so that the wheel ( Rear wheel 3) Apply braking force to the vehicle.
- the rear wheel side disc brake 6 is driven by the electric motor 78 via the rotary/linear motion mechanism 8 in response to an operation request based on a signal from the parking brake switch 23, as will be described later.
- Drive 0 to apply braking force (parking brake, auxiliary brake if necessary) to the vehicle.
- the rear wheel side disc brake 6 drives the electric motor 78 and propels the viston 60 by the rotary direct acting member 88, thereby pressing the brake pad 60 against the disc rotor 4. Hold.
- the rear wheel side disc brake 6 drives the piston 60 with the electric motor 78 in response to the parking brake request signal (Apply request signal) which is an apply request for applying the parking brake (parking brake). Therefore, it is possible to maintain the braking of the vehicle.
- the rear wheel side disk brake 6 is supplied with hydraulic pressure from a hydraulic pressure source (a master cylinder 12 described later, and a hydraulic pressure supply device 16 if necessary) according to the operation of the brake pedal 9. The vehicle can be braked.
- the rear wheel side disk brake 6 includes the rotation/linear motion mechanism 8 that presses the brake pad 60 against the disk rotor 4 by the electric motor 78 and holds the pressing force of the brake pad 60.
- the brake pad 6 (3 can be pressed against the disc rotor 4 by the hydraulic pressure applied separately from the pressing by the electric motor 78. ⁇ 2020/175 179 8 ⁇ (:171? 2020 /005742
- a pair (one set) of front wheel side disc brakes 5 provided corresponding to the left and right front wheels 2 are almost the same as the rear wheel side disc brakes 6 except for the mechanism related to the operation of the parking brake. It is similarly configured. That is, as shown in FIG. 1, the front wheel side disc brake 5 is provided with a mounting member (not shown), a cavern 58, a brake pad (not shown), a piston 5 m, etc. It does not have an electric actuator 7 (electric motor 78) for operating and releasing the brake, and a rotary/linear motion mechanism 8 etc.
- the front wheel-side disc brake 5 propels the piston 5 wheel by hydraulic pressure generated based on the operation of the brake pedal 9 and the like, and applies braking force to the wheels (front wheel 2) and thus the vehicle.
- the front wheel disc brake 5 is a hydraulic brake mechanism (hydraulic brake) that applies a braking force by pressing the brake pad against the disc rotor 4 with hydraulic pressure.
- the front wheel side disc brake 5 may be a disc brake with an electric parking brake function, like the rear wheel side disc brake 6.
- a hydraulic disc brake 6 having an electric parking mechanism is used as the electric parking brake device.
- the electric parking brake device is not limited to this, and for example, a hydraulic drum brake having an electric parking mechanism, a hydraulic disk brake having an electric drum parking mechanism, or a cable pulled by an electric motor. It is also possible to use a hydraulic disc brake, a drum brake, or the like equipped with an electric parking mechanism of a cable blur type that applies the parking brake by the above.
- the electric parking brake device presses (promotes) the friction member (pad, shoe) against the rotating member (rotor, drum) based on the drive of the electric motor (electric actuator), and holds and releases the pressing force.
- Various electric parking brake devices can be used as long as the structure has an electric parking mechanism capable of performing the above.
- a brake pedal 9 is provided on the front board side of the vehicle body 1.
- the brake pedal 9 is depressed by the driver when operating the vehicle brakes. ⁇ 2020/175 179 9 ⁇ (:171? 2020 /005742
- the brake pedal 9 is provided with a brake lamp switch, a pedal switch (brake switch), a brake operation detection sensor (brake sensor) 10 such as a pedal stroke sensor.
- the brake operation detection sensor 10 detects whether or not the brake pedal 9 is depressed, or the amount of operation thereof, and outputs the detection signal to the control device 3 (3 control device 17).
- the detection signal of 10 is, for example, the vehicle data bus 20 or It is transmitted via a communication line (not shown) connecting the control device 17 and the parking brake control device 24 (output to the parking brake control device 24).
- the depression operation of the brake pedal 9 is transmitted to the master cylinder 12 functioning as a hydraulic pressure source (hydraulic pressure source) via the booster 11.
- the booster 11 is configured as a negative pressure booster (pneumatic booster) or an electric booster (electric booster) provided between the brake pedal 9 and the master cylinder 12.
- the booster 11 increases the pedaling force and transmits it to the master cylinder 12 when the brake pedal 9 is depressed.
- the master cylinder 12 generates hydraulic pressure by the brake fluid supplied (supplemented) from the master reservoir 13.
- the master reservoir 13 serves as a hydraulic fluid tank containing a brake fluid.
- the mechanism for generating the hydraulic pressure by the brake pedal 9 is not limited to the above-mentioned structure, and may be a mechanism for generating the hydraulic pressure according to the operation of the brake pedal 9, for example, a brake-by-wire system mechanism. Good.
- the hydraulic pressure generated in the master cylinder 12 is supplied to the hydraulic pressure supply device 1 6 (hereinafter referred to as 85 0 1 6) via, for example, a pair of cylinder side hydraulic pressure pipes 14 and 14. Sent to. Mimi 1 6 is arranged between each disk brake 5, 6 and the master cylinder 12.
- Numeral 3 0 16 is the hydraulic pressure output from the master cylinder 12 via the cylinder side hydraulic piping 1 4 and 1 4 and the brake side piping. ⁇ 2020/175 179 10 boxes (: 171-1? 2020 /005742
- each disc brake 5, 6 It is supplied to each disc brake 5, 6 via 1 5 8 1, 15 5, 150, 150. That is, in the case of M3, the hydraulic pressure (break hydraulic pressure) corresponding to the operation of the brake pedal 9 is applied to the disc brakes 5, 6 (carriage brakes) provided on each wheel (each front wheel 2, each rear wheel 3). 5 8 and 6). This makes it possible to apply the braking force to each of the wheels (each front wheel 2, each rear wheel 3) independently of each other.
- £01 6 is a hydraulic pressure control device that controls the hydraulic pressure of the hydraulic brakes (the front wheel side disc brake 5 and the rear wheel side disc brake 6).
- £3016 is a multiple control valve, a hydraulic pump that pressurizes the brake hydraulic pressure, an electric motor that drives the hydraulic pump, and a hydraulic pressure that temporarily stores excess brake fluid. And a control reservoir (none of which is shown).
- the respective control valves and electric motors of the MINO 3016 are connected to the MINO 3 (3 control unit 17 and the MINO 3 16 is configured to include the MINO 3 control unit 17.
- the 3 (3 control unit 17 is a control unit for 30 (3) control unit (3) for controlling the 3 (316).
- the control unit 17 is a micro unit. It is configured to include a computer to electrically drive and control £01 6 (solenoid of each control valve, electric motor).
- the M30 control device 17 is, for example, £01 6 of liquid. It has a built-in computing circuit that controls the pressure supply and detects a £3016 failure, a drive circuit that drives the electric motor and each control valve (all not shown), and so on.
- the 3 (3 control unit 17 individually drives and controls each control valve (solenoid) of £01 6 and the electric motor for the hydraulic pump. 1 7 is for controlling the brake fluid pressure (wheel cylinder fluid pressure) supplied to each disc brake 5, 6 through the brake side pipe section 1 5 8 _ 1 50 to reduce, maintain, increase or increase the pressure of each disc. Perform each brake 5, 6 individually.
- the 3(3) control unit 17 can execute the following control (1)_(8), for example. ) car ⁇ 2020/175 179 1 1 ⁇ (:171? 2020 /005742
- Braking force distribution control that appropriately distributes braking force to each wheel 2 and 3 according to the ground load, etc., when braking both.
- Anti-lock brake control (hydraulic pressure 8 control) that automatically adjusts the braking force of each wheel 2 and 3 during braking to prevent lock (slip) of each wheel 2 and 3.
- Vehicle stabilization control that suppresses and stabilizes vehicle behavior.
- Slope start assist control that keeps the braking condition and assists the start on slopes (especially uphill slopes).
- Traction control to prevent each wheel 2, 3 from idling when starting.
- Vehicle-following control that maintains a constant distance from the preceding vehicle.
- Lane departure avoidance control that keeps the driving lane.
- Obstacle avoidance control (automatic brake control, collision damage reduction brake control) that avoids collisions with obstacles in the vehicle's traveling direction.
- £ 3 0 16 is the hydraulic pressure generated in the master cylinder 12 during the normal operation by the driver's brake operation, and is transferred to the disk brakes 5 and 6 (the calibers 58 and 6). Supply directly.
- the control valve for pressure when closing the control valve for pressure increase to hold the hydraulic pressure of the disc brakes 5 and 6 and reduce the hydraulic pressure of the disc brakes 5 and 6, The control valve for pressure reduction is opened and the hydraulic pressure of the disc brakes 5 and 6 is discharged so as to escape to the hydraulic pressure control reservoir.
- the controller 3 (3 controller 17 is connected to the vehicle data bus 2 ⁇ 2020/175 179 12 boxes (: 171-1? 2020 /005742
- the vehicle data bus 20 is provided as a serial communication unit mounted on the vehicle body 1. Eighty-six "68 1
- the wheel cylinder fluid pressure (/ ⁇ fluid pressure) is detected / ⁇ Pressure sensor 21 1, master cylinder fluid pressure
- the pressure sensor 22 is, for example, connected to the control device 17 as in the case of the brake operation detection sensor 10.
- the detection signal of the pressure sensor 22 is sent to the vehicle data bus 20 from the control device 3 (3 control device 17 as information on / ⁇ hydraulic pressure and 1 ⁇ /1/ ⁇ hydraulic pressure. Many mounted on the vehicle.
- Electronic devices can obtain various vehicle information including ⁇ / ⁇ //0 hydraulic pressure and hydraulic pressure through the vehicle data bus 20.
- Kasensor 2 1 and/or The pressure sensor 22 may be connected directly to the parking brake controller 24. ⁇ 2020/175 179 13 ⁇ (: 171? 2020 /005742
- a parking brake switch ( ⁇ _ 3 ⁇ /) as a switch for an electric parking brake is provided.
- the parking brake switch 23 serves as an operation instruction unit operated by the driver.
- the parking brake switch 23 sends a signal (operation request signal) corresponding to a parking brake operation request (an apply request, which is a holding request, a release request, which is a release request) in response to a driver's operation instruction to the parking brake control device.
- a parking brake operation request an apply request, which is a holding request, a release request, which is a release request
- the parking brake control unit 24 is a parking brake control unit (parking brake II).
- the Apply request signal (parking brake request signal, Apply command) is output from the switch 23.
- electric power for rotating the electric motor 78 to the braking side is supplied to the electric motor 7 of the rear wheel side disc brake 6 through the parking brake control device 24.
- the rotation/linear motion mechanism 8 propels (presses) the piston 60 toward the disc rotor 4 side based on the rotation of the electric motor 78, and holds the propelled piston 60.
- the rear wheel side disc brake 6 is brought into a state in which a braking force as a parking brake (or an auxiliary brake) is applied, and is immediately in an apply state (braking holding state).
- the release request signal (parking brake release request signal) from the parking brake switch 23. , Release command) is output.
- the electric motor 78 of the rear wheel side disc brake 6 is supplied with electric power for rotating the electric motor 78 in the direction opposite to the braking side through the parking brake control device 24.
- the rotation/linear motion mechanism 8 releases the holding of the piston 60 by the rotation of the electric motor 78 (releases the pressing force by the piston 6 port).
- the rear wheel side disc brake 6 is brought into a state where the application of the braking force as the parking brake (or the auxiliary brake) is released, that is, the release state (braking release state).
- the parking brake is used, for example, when the vehicle stops for a predetermined time (for example, the speed detected by the vehicle speed sensor is 5 When the engine stops, the shift lever is operated to (parking), the door is opened, the seat belt is released, etc. Based on the automatic apply request by the parking brake apply determination logic in the brake control device 24, it is possible to automatically apply (sait to apply).
- the parking brake operates the accelerator pedal when the vehicle is running (for example, when the vehicle speed is increased and the speed detected by the vehicle speed sensor continues to be 6 or more for a predetermined period of time). When the clutch pedal is operated, the shift lever is operated other than 1 ⁇ ], etc., based on the automatic release request by the parking brake release determination logic in the parking brake controller 2 4.
- Saiichi Toapurai Saiichi DOO release can be configured when Pas _ Kingubure _ Kisuitchi 2 3 fails, the switch failure when the auxiliary function for granting or automatically disengages the braking force.
- the parking brake controller 24 issues a braking command (for example, a fluid pressure request signal, a target fluid pressure signal) according to the operation of the parking brake switch 23 to the vehicle data bus 20 or the communication.
- a braking command for example, a fluid pressure request signal, a target fluid pressure signal
- the control device 3 controls the parking brake switch 2 3 to switch to the braking side based on the braking command from the parking brake control device 2 4. While being operated (while the operation to the braking side is continuing), the braking force by hydraulic pressure is applied, and when the operation is completed, the application of braking force by hydraulic pressure is released.
- the parking brake switch 23 when the parking brake switch 23 is operated while the vehicle is traveling, instead of applying and releasing the braking force by £300, for example, an electric motor of the rear wheel side brake 6 is used. It is possible to apply and release the braking force by the drive of 7-8.
- the parking brake control device 24 applies a braking force while the parking brake switch 23 is operated to the braking side (while the operation to the braking side is continued), and the operation is performed. When is finished, the control is released. At this time, the parking brake controller 24 automatically applies and releases the braking force according to the state of the vehicle wheels (rear wheels 3), that is, whether the wheels are locked (slipped) (S3). Control).
- the parking brake control device 24 as a control device constitutes a brake system together with the rear wheel side disc brake 6 (hydraulic braking device, electric braking device).
- the parking brake controller 24 controls driving of the electric motor 78. That is, the parking brake control device 24 has a control part for controlling the drive of the electric motor 78 in the rear wheel side disc brake 6. For this reason, as shown in FIG. 3, the parking brake control device 24 has an arithmetic circuit ( ⁇ II) 25 and a memory 26 which are configured by a microcomputer or the like.
- Parking brake controller 2 4 ⁇ 2020/175 179 16 ⁇ (:171? 2020 /005742
- the parking brake control device 24 controls the drive of the electric motors 7, 7 of the rear wheel side disc brakes 6, 6 so that the braking force is applied when the vehicle is parked or stopped (when necessary, running). (Parking brake, auxiliary brake) is generated. That is, the parking brake controller 24 drives the left and right electric motors 78 and 78 to operate the disk brakes 6 and 6 as parking brakes (auxiliary brakes as necessary) (Apply Release). ..
- the parking brake control device 24 is connected on the input side to the parking brake switch 23 and on the output side to the electric motors 78 of each disc brake 6, 6.
- the parking brake control device 24 detects the driver's operation (operation of the parking brake switch 23), determines whether the electric motors 78, 78 can be driven, determines whether the electric motors 78, 78 are stopped, etc. It has a built-in arithmetic circuit 25 for performing the above, and motor drive circuits 28, 28 for controlling the electric motors 78, 78.
- the parking brake control device 24 is an operation request by the driver's operation of the parking brake switch 23 (apply request, release request), an operation request by the parking brake apply/release determination logic, and the Hachimi 3 control.
- the left and right electric motors 7, 7 are driven based on the operation request by, and the left and right disc brakes 6, 6 are applied (holding) or released (released).
- the rotation/linear motion mechanism 8 holds or releases the piston 60 and the brake pad 60 based on the drive of each electric motor 7.
- the parking brake control device 24 responds to the operation request signal for holding (apply) or releasing (release) the piston 60 (and thus the brake pad 60). Drive and control the electric motor 78 to propel 60 (and thus the brake pad 60).
- the arithmetic circuit 25 of the parking brake controller 2 4 has ⁇ 2020/175 179 17 ⁇ (:171? 2020/005742
- a parking brake switch 23 In addition to the memory 26 as a storage unit, a parking brake switch 23, a vehicle data bus 20, a voltage sensor unit 27, a motor drive circuit 28, a current sensor unit 29, etc. are connected. From the vehicle data bus 20, various state quantities of the vehicle necessary for controlling (operating) the parking brake, that is, various vehicle information can be acquired. Further, the parking brake controller 24 can output information and commands to various vehicles (3 II including the vehicle 3 (3 control apparatus 17) via the vehicle data path 20 or the communication line.
- the vehicle information acquired from the vehicle data bus 20 has a configuration in which a sensor for detecting the information is directly connected to (the arithmetic circuit 25 of the parking brake control device 2 4).
- the arithmetic circuit 25 of the parking brake control device 24 is connected to the vehicle data bus 20 by another control device (for example, the control device 3 (3 control device 17) and the above-mentioned judgment logic and control device 3).
- the parking brake controller 2 4 is used instead of the parking brake controller 2 4 for determining whether the parking brake is applied or released by the above-described judgment logic or controlling the Hachimi 3. It is possible to adopt a configuration in which another control device, for example, the 3 (3 control device 17) is used. That is, the control content of the parking brake control device 2 4 can be integrated into the 3 (3 control device 17). It is possible.
- the parking brake controller 24 is, for example, a flash memory
- a memory 26 is provided as a storage unit including the above.
- the memory 26 stores the above-mentioned parking brake application/release judgment gick and the program for controlling the Hachimi 3.
- the memory 26 stores a processing program for executing the processing flow shown in FIGS. 4 to 6, which will be described later, that is, a processing program used for control processing at the time of applying the electric parking brake. ..
- the memory 26 stores the relationship between the hydraulic pressure and the stop current threshold during apply 3 36 shown in Fig. 7, which will be described later, and the amount of change in the hydraulic pressure ⁇ and the re-energization time 1 shown in Fig. 8: " ⁇ The relationship with is also stored.
- the parking brake control device 24 is set to the control device 30. ⁇ 2020/175 179 18 ⁇ (: 171? 2020 /005742
- the parking brake controller 24 and the counter 3 ⁇ 3 controller 17 may be integrated (that is, integrated by one braking controller).
- the functions of the parking brake control device 2 4 are integrated in the 3 (3 control device 17), and the rear wheel side disc brakes 6, 6 and the parking switch 2 3 are connected to the 3 (3 control device 17).
- the 3 (3 control device 17 stores the brake control program shown in FIGS. 4 to 6 described later, and the 3 0 control device 17 acts as a brake control device for the electric brake device.
- the parking brake control device 24 controls the two rear wheel side disc brakes 6, 6 on the left and right sides, but the left and right rear wheel side disc brakes 6, 6 are controlled.
- the parking brake control device 24 of the parking brake control device 24 may be provided integrally with the rear wheel side disc brake 6.
- the parking brake control device 24 has a power line 1
- Voltage sensor part 27 for detecting the voltage from 9, left and right motor drive circuits 28, 28 for driving the left and right electric motors 78, 78, left and right electric motors 78, 78 respectively
- the left and right current sensor units 29, 29 that detect the current are built in.
- the voltage sensor unit 27, the motor drive circuit 28, and the current sensor unit 29 are connected to the arithmetic circuit 25, respectively.
- the arithmetic circuit 25 of the parking brake controller 24 when the parking brake is applied or released, the current value (change) of the electric motor 78 detected by the current sensor 29 is detected. Based on this, it is possible to determine whether the driving of the electric motor 78 is stopped (determination of Apply completion, release completion) and the like.
- the voltage sensor unit 27 is configured to detect (measure) the power supply voltage.
- the voltage sensor unit (voltage sensor) is used between the terminals of the electric motors 78 and 78. The voltage may be measured independently on the left and right sides.
- the above-mentioned brake system of Patent Document 1 corrects the current threshold value in accordance with the hydraulic pressure to suppress an excessive thrust generated due to the driving of the electric motor. That is, the electric parking brake is ⁇ 2020/175 179 19 ⁇ (:171? 2020/005742
- the biston may be propelled not only by the thrust of the electric motor but also by the hydraulic pressure, and the piston thrust after the hydraulic pressure is released (hereinafter referred to as the holding thrust) may become excessive. ..
- the holding thrust it is effective to control the thrust by adjusting the thrust generated based on the drive of the electric motor according to the hydraulic pressure.
- the hydraulic pressure used for control control-recognized hydraulic pressure
- the holding thrust may be insufficient.
- Patent Document 1 by providing a margin in advance to the thrust control amount of the electric motor with respect to the hydraulic pressure and generating a high thrust, it is possible to suppress insufficient holding thrust. That is, in Patent Document 1, a shortage of thrust is suppressed by providing a margin in consideration of the dynamic characteristics of hydraulic pressure when correcting the current threshold value.
- the control recognition hydraulic pressure for the true value of the Caliba hydraulic pressure is, for example, communication delay due to reception (acquisition) via ⁇ (vehicle data bus 20), An error (fluid pressure error) may occur when the hydraulic pressure changes due to the delay caused by the filter.
- a hydraulic pressure error due to a sudden decrease in hydraulic pressure is taken into consideration in advance, and a margin is provided for the control amount of the thrust by the electric motor with respect to the hydraulic pressure, thereby preventing the insufficient holding thrust.
- the electric motor 78 is driven according to the hydraulic pressure. ⁇ 2020/175 179 20 boxes (:171? 2020 /005742
- the following configuration is adopted so that the hydraulic pressure can be detected accurately and excessive holding thrust can be suppressed. That is, in the first embodiment, the energization of the electric motor 78 is temporarily stopped during the application, that is, during the generation of the thrust at the time of the application. At this time, the error between the true value of the carrier pressure and the control-recognized hydraulic pressure due to the hydraulic pressure delay is estimated from the hydraulic pressure change in the range including the suspension of energization.
- the necessity of re-driving the electric motor 78 after temporary suspension of energization (necessity of additional tightening) and the re-driving amount of the electric motor 7 (additional tightening ) Is determined.
- the change in hydraulic pressure is reduced, the thrust is reduced, so the tightening amount (reenergization time) is increased.
- the change in hydraulic pressure is increased, the amount of additional tightening (reenergization time) is reduced, or the additional tightening is not performed (reenergization time is set to ⁇ ).
- the parking brake control device 24 (the control unit thereof) controls the electric motor 7 8 in the section where the thrust is generated in the piston 60 when the braking force is retained. Temporarily stop the power supply to. That is, the parking brake control device 24 (the control unit thereof) drives the electric motor 78 according to the parking brake request signal (control command) that holds the braking force, and thrust is generated at the piston 6 mouth. When the current rises, the power supply to the electric motor 78 is temporarily stopped. In this case, the suspension time is set to a time longer than the delay time of hydraulic information (and shorter than 1 to 2 seconds, for example).
- the application may be terminated after restarting the power supply (complete), or the application may be terminated without restarting the power supply. (Completed) In the following explanation, do not restart the power supply. ⁇ 2020/175 179 21 ⁇ (:171? 2020 /005742
- the parking brake control device 2 4 (the control unit thereof) operates the electric motor 7 8 in response to a parking brake request signal (control command) from the parking brake switch 23 or the above-described parking brake operation determination logic. Start driving. In this case, the parking brake control device 24 first drives the electric motor 78 until it reaches a current threshold value for temporarily stopping the drive of the electric motor 78 (stop current threshold value during apply 3-6).
- the current threshold (current threshold for applying current I 3 3 ⁇ ) is set so that the electric power supply to the electric motor 78 can be stopped in the section where thrust is generated in the piston 60 by driving the electric motor 78. There is. As a result, the parking brake control device 24 can temporarily stop the power supply to the electric motor 78 in the section where thrust is generated in the piston 60.
- the parking brake control device 24 controls the hydraulic pressure information of the rear wheel side disk brake 6, that is, when the electric motor 78 is driven and is temporarily stopped. Detects or estimates (calculates) the fluid pressure (change) of.
- the liquid pressure inside the caliber 58 is: / ⁇ liquid pressure detected by the pressure sensor 21 / ⁇ liquid pressure / ⁇ , 1 ⁇ /1/ 1 liquid detected by the pressure sensor 2 2 Pressure 1 ⁇ /1/ ⁇ , 1 ⁇ /1/ ⁇ Calculated from hydraulic pressure 1 ⁇ /1/ ⁇ / ⁇ Fluid pressure/ ⁇ etc., fluid pressure directly corresponding to fluid pressure (/ ⁇ , 1 ⁇ In addition to being able to use /1/ ⁇ , it is possible to use information (state quantity) 3 that can estimate the hydraulic pressure 3. In the embodiment, as the hydraulic pressure, it is detected by the 1 ⁇ /1/ ⁇ pressure sensor 2 2. Use 1 ⁇ /1/ ⁇ hydraulic pressure 1 ⁇ /1/ ⁇ .
- the parking brake controller 24 starts to drive the electric motor 78 by the parking brake request signal, and then the hydraulic pressure in the carrier 58 is increased.
- the parking brake control device 24 temporarily supplies the electric power to the electric motor 7A in accordance with the hydraulic pressure P applied to the viston 5B when the holding of the braking force is started.
- the stop current threshold during apply (pause) (hereinafter also referred to as the temporary stop current threshold (pause)), which is the current threshold for stopping, is changed. That is, the parking brake control device 24 (the control unit thereof) acquires the hydraulic pressure P applied to the rear wheel-side disk brake 6 when starting to maintain the braking force, and responds to the acquired hydraulic pressure P.
- Set the stop current threshold at apply time pause to temporarily stop the power supply to the electric motor 7 A. As shown in Fig.
- the minimum value pm in is the electric current so that it can be determined that the thrust current threshold value is paused and the thrust is generated in the piston 6D based on the drive of the electric motor 7A.
- Current value in the section where the motor 7 A runs idle (section before the linear motion member 8 A 2 contacts the viston 6 D) (for example, about 1 to 3 A) ⁇ 2020/175 179 23 ⁇ (:171? 2020 /005742
- the temporary stop current threshold value 0 when the hydraulic pressure is 0 IV! 3 is, for example, the final thrust that should be applied only by driving the electric motor 78 while the hydraulic pressure is 0 IV! 3 ( It can be set to a value equal to or less than the current value corresponding to the thrust that can keep the vehicle stopped).
- the parking brake control device 24 (the control unit thereof) temporarily stops the electric power supply to the electric motor 78, and then, after a lapse of the suspension time, switches the electric brake to the electric motor 78 as necessary. To restart the power supply. Then, the parking brake control device 24 completes the retention (apply) of the braking force when the retention completion condition for completing the retention of the braking force is satisfied. In this case, the parking brake control device 24 (the control unit thereof) determines the holding completion condition based on the change in the vehicle state when the power supply is temporarily stopped.
- the holding completion condition is determined by the change in the hydraulic pressure applied to the piston 6 as the vehicle state. That is, the parking brake control device 24 (the control unit thereof) acquires the change in the hydraulic pressure applied to the piston 6 as the vehicle state, and temporarily stops the power supply based on the change in the hydraulic pressure.
- the holding completion condition after the process is determined.
- the holding completion condition is that the power supply time after the power supply is resumed is lengthened as the amount of change in the hydraulic pressure during the power supply is temporarily stopped is large. That is, the parking brake control device 24 (the control unit thereof) increases the power supply time after the power supply is resumed as the amount of change in the hydraulic pressure during the temporary stop of the power supply becomes longer.
- Set the retention completion condition More specifically, the larger the amount of decrease in hydraulic pressure (pressure reduction amount) while power supply is temporarily stopped, the longer the power supply time after resumption of power supply. On the other hand, the larger the amount of increase in hydraulic pressure (pressure increase amount) while power supply is temporarily stopped, the shorter the power supply time after power supply restarts, or ⁇ (do not restart). .. Parking brake system ⁇ 2020/175 179 24 ⁇ (:171? 2020 /005742
- the control device 24 should satisfy the holding completion condition determined based on the change in the vehicle state (hydraulic pressure), restart the electric motor 7 drive if necessary, and operate the electric motor under the determined holding completion condition. 7 eight stop.
- the parking brake control device 24 detects a hydraulic pressure error (control recognition value>true value) caused by delay of control recognition hydraulic pressure during depressurization during the temporary suspension of energization, and will be described later.
- the parking brake controller 24 detects a hydraulic pressure error (control recognition value ⁇ true value) caused by a delay in the control recognition hydraulic pressure at the time of increasing the pressure, and will be described later. Determine the power supply time (reenergization time 1 "6") after resuming energization based on Fig. 8.
- the parking brake control device 24 detects the hydraulic pressure fluctuation by using the hydraulic pressure in the state where the energization is temporarily stopped. Therefore, in the situation where there is no fluctuation in hydraulic pressure due to the fact that the piston 60 is propelled by the electric motor 78 (the hydraulic chamber expands). ⁇ 2020/175 179 25 ⁇ (:171? 2020 /005742
- the hydraulic pressure can be monitored. As a result, the hydraulic pressure detection accuracy can be improved, and also from this aspect, the holding thrust suppressing effect can be enhanced.
- the apply control of the electric motor 78 by the parking brake control device 24 when activating (applying) such a parking brake (control process of FIGS. 4 to 6) will be described later in detail.
- the brake system for a four-wheeled vehicle according to the first embodiment has the above-mentioned configuration, and its operation will be described next.
- the depressing force is transmitted to the master cylinder 12 via the booster 11 and brake fluid pressure is generated by the master cylinder 12.
- the brake fluid pressure generated in the master cylinder 1 2 is based on the cylinder side fluid pressure piping 1 48, 1 4 and £ 3 0 16 and the brake piping 1 5 8 and 1 5 and 1 5 0 and 1 5 It is supplied to each disc brake 5, 6 via 0, and braking force is applied to the left and right front wheels 2 and the left and right rear wheels 3, respectively.
- each disc brake 5 and 6 the pistons 5 and 60 are brake pads 6 ⁇ (only the rear wheel 3 side is shown) according to the increase in the brake fluid pressure in the calipers 58 and 6 respectively.
- the brake pad 60 is pressed against the disc brakes 4, 4 by slidingly moving toward. As a result, a braking force based on the brake fluid pressure is applied.
- the brake operation is released, the supply of brake fluid pressure into the carriages 58 and 6 is stopped, so that the pistons 5 and 60 are separated (retreated) from the disc rotors 4 and 4. Is displaced to.
- the brake pad 6 (3 is separated from the disc rotors 4, 4 and the vehicle is returned to the non-braking state.
- the parking brake control device 2 4 causes the electric motor 7 8 of the left and right rear wheel side disc brakes 6 to be operated. Power is supplied to the electric motor and the electric motor 78 is driven to rotate. In the rear wheel side disc brake 6, the rotary motion of the electric motor 7 is converted into a linear motion by the rotary/linear motion mechanism 8 and the piston 60 is propelled by the rotary/linear motion member 8. This allows the brake pad 60 to ⁇ 2020/175 179 26 ⁇ (:171? 2020 /005742
- the rotary direct-acting mechanism 8 (the direct-acting member 8A2) is held in the braking state by, for example, a frictional force (holding force) due to screwing.
- the rear wheel side disc brake 6 is operated (applied) as a parking brake. That is, even after the electric power supply to the electric motor 7A is stopped, the rotary/direct-drive mechanism 8 holds the viston 6D in the braking position.
- the parking brake control device 24 supplies electric power to the electric motor 7 A so that the motor reverses.
- the electric motor 7 A is rotated in the direction opposite to that when the parking brake is activated (when applied).
- the holding of the braking force by the rotary direct acting mechanism 8 is released, and the piston 6D can be displaced in the direction away from the disc rotor 4.
- the operation of the rear wheel side disc brake 6 as the parking brake is released.
- FIG. 5 is the process following FIG. FIG. 6 corresponds to S 9 “AP judgment processing” in FIG.
- the control processes of FIGS. 4 to 6 are repeatedly executed at a predetermined control cycle (for example, 1 O msec) while the parking brake control device 24 is energized. Note that these processes are executed by the parking brake control device 24, which is a brake control device, as a brake control program as well as a brake control method for controlling the electric motor 7A.
- the Apply control process of Fig. 4 is started.
- the parking brake controller 24 determines in S1 whether or not the apply operation flag is ⁇ N.
- the Apply in-operation flag is a determination flag for determining whether or not Apply is in operation.
- the flag during Apply operation becomes ⁇ N during Apply operation, that is, from the start to the end of Apply including the temporary stop of the drive of the electric motor 7A. Specifically, ⁇ 2020/175 179 27 ⁇ (: 171? 2020 /005742
- the Apply flag is turned ON. It also drives the electric motor 7 A in the Apply direction.
- the Apply flag is set to ⁇ N, and when driving of the electric motor 7A in the Apply direction is started, proceed to S4.
- S 3 corresponds to the step of starting the power supply to the electric motor 7 A in response to a control command (apply command) for holding the braking force of the rear wheel side disc brake 6.
- the timer the inrush current progress determination timer starts counting.
- the inrush current mask time is the time after the electric motor 7 A starts operating in the apply direction, and the time for the inrush current to settle sufficiently is set. If “N0" is determined in S4, that is, if it is determined that the elapsed time by the inrush current elapsed determination timer has not passed the inrush current mask time, the process returns. This makes it less susceptible to the inrush current when determining the stop current threshold at apply I pause at S6, that is, the current value due to the inrush current is the stop current threshold at apply ⁇ pause or apply complete current. This is to prevent erroneous detection of stop at apply or completion of apply exceeding the threshold value cut. On the other hand, if “YES” in S4, that is, if it is determined that the inrush current mask time has elapsed, the process proceeds to S5. ⁇ 2020/175 179 28 ⁇ (: 171? 2020 /005742
- the stop flag at the time of apply is 0 ⁇ 1 ⁇ 1.
- the stop flag during ably is a judgment flag for judging whether the energization was temporarily stopped during the apply operation.
- the power supply to the electric motor 78 is temporarily stopped, it becomes 0 ⁇ 1 ⁇ 1.
- the processing of 37 described later results in 0 1 ⁇ 1
- the processing of 3 15 results in 0.
- the suspension current threshold value 3-3 36 has a high hydraulic pressure (master cylinder hydraulic pressure) acquired via 088 1 ⁇ 1 (vehicle data bus 20). I see, it's set lower. However, in order not to mistakenly determine the temporary stop due to the current in the no-load state, the current is not suppressed below the lower limit value ⁇ n.
- the lower limit value ⁇ n is that the braking force (thrust) is generated (the direct-acting member 88,2 comes into contact with the piston 60 to generate thrust), which is a reliable current value, in other words, the electric motor 7
- the thrust is generated in the piston 60 by the drive of the eight, which corresponds to a certain current value.
- ⁇ !11 ⁇ is set as a value (for example, about 58) that is higher than the current value (idling current 0, for example, 18 to 38) before the braking force is generated.
- the solid characteristic line 3 1 is different from the dashed characteristic line 3 2 which is the relationship between the ideal hydraulic pressure not considering the error and the temporary stop current threshold value 3 3 36.
- This offset (margin) is set to be larger than the hydraulic pressure error (the hydraulic pressure recognition value is greater than the true value) in the direction of thrust reduction that occurs in the hydraulic pressure due to “factors other than delay”.
- the “delay” is, for example, the calculation of an electronic device (control unit: Mimi 30 control device 17 and parking brake control device 24) that processes the communication delay and hydraulic pressure by the vehicle data bus 20. Delay (processing delay) can be mentioned.
- the offset ⁇ does not include such a delay, and an error due to “a factor other than the delay”, for example, It is set larger than the hydraulic pressure error due to the unavoidable detection error (sensor error) of pressure sensor 22.
- step 3 8 it is determined whether the preset Apply pause time has elapsed since the Apply stop flag became 0 1 ⁇ 1. If it is determined in step 3 8 that “3”, that is, the stop time at the time of apply has elapsed, “8” in Figure 4 is displayed.
- the stop time at the time of apply is set to be longer than the delay time of hydraulic pressure. This makes it possible to determine the occurrence of an error due to the delay in hydraulic pressure in the subsequent 38th determination process.
- Judgment processing is performed. 3
- the determination process is the process shown in FIG. 3 In the judgment process, the amount of change in hydraulic pressure during the temporary suspension of energization Based on (2-1), the power supply time after resuming energization (reenergization time 1 To determine. That is, in 39, the reenergization time 1 including whether or not to reenergize after the energization suspension time elapses based on the change amount ⁇ of the hydraulic pressure when the power supply is temporarily stopped. To decide. In 38, it is judged as “3” 39, that is, when it proceeds to 39 _ 1 in Fig.
- re-energization time 1 “6 has been calculated. 39— 1 If it is determined that "N0”, that is, the re-energization time I " 6 has not been calculated, the process proceeds to 39-2. In 39-1 "Re-power 3", that is, the re-energization time " 6 " is calculated. If it is determined that the power supply has been completed, proceed to 310 in Fig. 5 through the return in Fig. 6. Re-energization time "6 is the time (7 Power supply time).
- reenergization time I Is determined (calculated). 39-3 corresponds to the step of setting the holding completion condition based on the change in the vehicle state when the electric power supply to the electric motor 78 is temporarily stopped.
- Re-energization time which is the condition for holding completion Is determined using, for example, the map (characteristic diagram) shown in Fig. 8. ⁇ 2020/175 179 31 ⁇ (:171? 2020/005742
- the amount of change ⁇ P is equal to or greater than the hydraulic pressure change threshold value ⁇ P max (when the change in pressure increase is large)
- the re-energization time tre becomes 0 (no re-energization and no retightening).
- the longer the power supply time after re-energization APmax is, for example, the relationship between the stop current threshold value at appraisal pause and the change amount ⁇ P.
- S9—3 is the vehicle state, and is the hydraulic pressure applied to piston 6D. This corresponds to the step of acquiring the change and setting the holding completion condition based on the change in the hydraulic pressure.
- S 9-3 is the amount of change in the hydraulic pressure while the power supply is temporarily stopped. Corresponds to the step of setting the holding completion condition so that the larger the value, the longer the power supply time after the power supply is restarted.
- 3 1 3 it is determined whether or not the elapsed time after restarting the power distribution (count time of the power distribution restart timer) exceeds the re-powering time I “ 6 calculated in 3 9 _ 3 in FIG.
- the holding completion condition for completing the holding of the braking force stopping the electric motor 78
- 3 1 3 "3” that is, the time after the power supply to the electric motor 78 is restarted (counting time of the power supply restart timer) has passed the re-powering time "6 (holding completion condition was satisfied. ), the process proceeds to 3 1 4.
- 3 1 3 “N 0 ”, that is, the time after the power supply to the electric motor 78 is restarted (the energization restart timer count time) is reset. If it is judged that the energization time has not exceeded “6 (holding completion condition not satisfied), return.
- the Apply complete flag is set to 0 ⁇ 1 to stop the re-driving (re-energization) of the electric motor 78, and the process proceeds to 3 1 5.
- 3 1 5 clears each timer (inrush current passage judgment timer, energization restart timer) and flags (apply in-operation flag, apply stop flag, ply completion flag flag). That is, each flag is set to 0 and each flag is set to 0. Also, at 3-15, the power supply to the electric motor 78 is stopped (completely stopped even while the power supply is temporarily stopped). ⁇ 2020/175 179 33 ⁇ (:171? 2020/005742
- 3 15 corresponds to the step of completing the holding of the braking force when the holding completion condition for completing the holding of the braking force is satisfied.
- Fig. 9 shows an example of the time chart (time change of the motor current and the hydraulic pressure at the time of applying) when the processing shown in Figs. 4 to 6 is performed by the parking brake controller 24.
- the hydraulic chamber is expanded by propelling the piston 60 based on the drive of the electric motor 78 while a constant hydraulic pressure is applied, and the hydraulic chamber expands with the expansion of the hydraulic chamber. It shows the case where the pressure drops. Note that, for example, the case where the hydraulic pressure changes (decreases) based on the operation of the brake pedal 9 can be considered in the same manner.
- the hydraulic pressure indicates the hydraulic pressure (control-recognized hydraulic pressure) that the parking brake controller 24 recognizes via ⁇ (vehicle data bus 20).
- the parking brake control device 24 supplies electric power to the electric motor 78 and drives the electric motor 78 in the apply direction. At this time, the electric motor 78 shifts from the stopped state to the driven state, so that a large inrush current occurs once, and then decreases and is maintained at a constant value (current value 0).
- current value current value is 0
- the current is constant (current value is 0)
- the motor current begins to rise. From this point, the section where thrust is generated in the piston 60 starts, and the current supplied to the motor 78 rises as the transmission thrust to the piston 60 increases.
- the hydraulic pressure decreases as the hydraulic chamber expands due to the thrust of the piston 60. In this case, the hydraulic pressure recognized by the parking brake control device 24 begins to decrease after the motor current begins to increase due to the delay described above.
- the parking brake control device 24 performs the process of 36 in Fig. 4 based on the "hydraulic pressure at that time” and the "characteristic line 3 1 in Fig. 7" to determine whether the electric brake is applied during the applying. Set the stop current threshold during apply that temporarily stops the power supply. At time 1, when the motor current is applied according to the hydraulic pressure at that time, ⁇ 2020/175 179 34 ⁇ (:171? 2020 /005742
- the parking brake controller 24 restarts energizing the electric motor 78 at the time 2 when the stop time at the time of apply has elapsed.
- Parking brake controller 2 4 Re-energization time after re-energization 1
- the energization (re-energization) to the electric motor 78 is stopped, and the apply process ends.
- the re-energization time “6 is 0 the retention completion condition is that the energization is not restarted. Therefore, the apply process ends at time 2 when the stop time at the time of apply has elapsed.
- the holding completion condition (re-energization time “6”) for completing the holding of the braking force is set.
- the holding of the braking force should be completed under the holding completion condition (reenergization time 1 "6") corresponding to the change of the vehicle state (hydraulic pressure).
- the influence (error) due to the delay of the vehicle state information for example, hydraulic pressure information
- the vehicle state (change of) at that time is suppressed.
- the stop current threshold during application 3 to 3 ⁇ for temporarily stopping the power supply to the electric motor 78 is changed according to the hydraulic pressure. For this reason, the power supply to the electric motor 78 can be temporarily stopped with an appropriate stop current threshold value during application according to the hydraulic pressure. That is, the power supply can be suspended before the thrust becomes excessive. Then, when it is necessary to restart the power supply based on the change in the vehicle state (hydraulic pressure) when the vehicle is temporarily stopped, restarting the power supply can suppress the lack of thrust.
- the holding completion condition for completing the holding of the braking force is determined by the change in hydraulic pressure. Therefore, the holding of the braking force can be completed under the holding completion condition (re-energization time I “6”) corresponding to the change of the hydraulic pressure.
- Amount of change in hydraulic pressure during temporary stop I larger, and more specifically, the larger the hydraulic pressure changes to the pressure reduction side (the larger the pressure reduction amount), the longer the re-energization time “6”, which is the power supply time after the power supply is restarted. For this reason, in order to prevent the thrust from becoming excessive, even if the power supply is temporarily stopped when the thrust is low, it is possible to suppress the thrust shortage when the braking force is completely retained.
- FIGS. 10 to 12 show a second embodiment.
- the feature of the second embodiment is that, when the power supply is temporarily stopped during application, “the power supply is restarted to reach a predetermined current threshold and then the power supply is stopped. It is about deciding whether to end Apply or end Apply without restarting.
- the second embodiment are denoted by the same _ sign the same components as those of the first embodiment, description thereof will be omitted.
- the apply is completed based on the change in the vehicle state (hydraulic pressure). Determine the conditions.
- the re-energization time 1 "6 (holding completion condition) after the energization suspension is determined based on the pressure difference before and after the energization temporary stop during application.
- the energization is restarted after the energization is stopped based on the pressure difference between before and after the energization is stopped during applying. ⁇ 2020/175 179 36 ⁇ (:171? 2020 /005742
- the stop current threshold value at the time of Apply is determined based on the map (not shown) similar to the map shown in Fig. 7 described above. 3) 3 ⁇ is decided.
- the offset ⁇ is only the hydraulic pressure error in the thrust reducing direction (the hydraulic pressure recognition value is larger than the true value) due to factors other than delay such as sensor error occurring in the hydraulic pressure.
- it is set larger than the hydraulic pressure error due to the delay that occurs in the normal range. That is, the offset 0 of the second embodiment has a larger value than the offset 0 shown in FIG. 7 of the first embodiment.
- the relationship between the hydraulic pressure and the threshold current for stopping current at the time of applying 8 3 ⁇ in the second embodiment is, for example, the characteristic line 3 1 in FIG. Can be set as a characteristic line.
- the suspension current threshold value ⁇ when the hydraulic pressure is 0 IV! 3 can also be made larger than the suspension current threshold value 0 of the characteristic line 31 in FIG.
- the memory 26 of the parking brake control device 24 stores a processing program for executing the processing flow shown in FIG. 4, FIG. 10, and FIG. ing.
- FIG. 10 is the process following FIG. FIG. 11 corresponds to the “ ⁇ ? determination process” of 32 1 in FIG. Since the control processing of FIG. 4 has been described in the first embodiment, the description thereof will be omitted. Further, the processing of 31 0, 31 1, 31 2, 31 4, 31 5 in FIG. 10 is the same as the processing of 31 0, 31 1, 31 2, 31 4, 31 5 in FIG. 5 described above. Yes, since 32 1 -2 and 32 1 -4 in FIG. 11 are similar to the processes of 39-2 and 39-5 in FIG. 6, their explanation is omitted.
- the ⁇ judgment process of 32 1 is the process shown in FIG. In the 8 judgment process of 32 1, it is determined whether or not to re-energize after the passage of the energization suspension time, based on the amount of change in hydraulic pressure during energization suspension ⁇ (92 91). In particular,
- the hydraulic pressure change threshold ⁇ 018 X is set to be smaller than the offset 0 which is a hydraulic pressure error margin.
- 32 1 — 3 means “3”, that is, the amount of change Is the fluid pressure change threshold
- 32 1 — 3 is “[3]”, that is, the amount of change ⁇ ? ( ⁇ 2020/175 179 38 ⁇ (: 171? 2020 /005742
- 3 2 1 — 3 is “N 0 ”, that is, if the amount of change ⁇ (fluid pressure change) during temporary suspension of power supply is determined to be equal to or greater than the hydraulic pressure change threshold ⁇ P max, then 3 The application completion flag is set to 0 1 ⁇ 1 in the process of 2 1-4, and the energization is not restarted (re-tightened) in the process after this. In this way, in 3 2 1 -3, the retention completion condition that terminates (completes) the Apply is determined.
- 3 2 2 of Fig. 10 it is determined whether or not the inrush current mask time has elapsed after resuming energization.
- the inrush current mask time after resuming energization is the time after resuming energization at 3 1 2. Set the time for the rush current to resume energization to fully converge. If it is determined in 3 2 2 that it is “3”, that is, if the inrush current mask time has elapsed after resuming energization, proceed to 3 2 3.
- 3 2 2 "N 0" that is, if it is determined that the inrush current mask time has not elapsed after resuming energization, return
- 3 2 3 it is determined whether or not the motor current is higher than the apply completion current threshold ⁇ ri ( ⁇ > ⁇ ⁇ ri 1:). That is, in 3 2 3, it is determined whether or not the holding completion condition determined when the power supply is temporarily stopped is satisfied. If 3 2 3 determines “N 0 ”, that is, the motor current is less than or equal to the apply completion current threshold I ⁇ ri 1: ((££ ⁇ ⁇ ri 1:)), the holding completion condition is not satisfied. Because there is, it returns. 3 2 3 If “3” is determined, that is, if the motor current I exceeds the apply completion current threshold ⁇ li ( ⁇ > ⁇ li 1:), the holding completion condition is satisfied. Therefore, proceed through 3 1 4 to 3 1 5.
- Fig. 12 shows the time chart when the processing shown in Fig. 4, Fig. 10 and Fig. 11 is performed by the parking brake control unit 24 (change in motor current and hydraulic pressure during application). Shows an example. At time 1 1, the motor current ⁇ 2020/175 179 39 ⁇ (:171? 2020 /005742
- the supply current to the electric motor 78 is temporarily stopped when the stop current threshold value during application according to the hydraulic pressure of the valve exceeds 3 .
- the parking brake control device 24 is Changes in hydraulic pressure If it is less than 3 X, the power is reopened after the stop time at the time of applying and the motor current exceeds the apply completion current threshold value ⁇ I, and it is determined as the holding completion condition.
- the parking brake controller 24 restarts the power supply to the electric motor 78 at the time 2 when the stop time at the time of apply has elapsed.
- the motor current value is the current threshold value. When it exceeds 1, the energization (re-energization) to the electric motor 78 is stopped and the apply process is completed.
- whether or not to restart energization is determined based on the amount of change in hydraulic pressure during suspension (more specifically, before and after suspension) of the electric motor 78 (more specifically, before and after suspension). If necessary, re-energize to suppress thrust excess and deficiency.
- the second embodiment performs an apply process including a temporary stop of power supply based on the process shown in Fig. 4, Fig. 10 and Fig. 11 as described above.
- the first embodiment there is no particular difference from that of the first embodiment. That is, also in the second embodiment, as in the first embodiment, it is possible to suppress the excess or deficiency of the thrust at the completion of the apply.
- the parking brake control device 24 causes the hydraulic pressure to be supplied via the route 08 (vehicle data bus 20).
- the following describes an example of a configuration in which the control signal is received and the apply control process is performed using this hydraulic pressure. ⁇ 2020/175 179 40 ⁇ (:171? 2020 /005742
- control (Apply control) may be performed based on the hydraulic pressure value.
- the vehicle state may be, for example, the operation amount of the brake pedal, the displacement amount of the input member (input car rod) of the booster, the rotation amount of the electric motor of the electric booster, or the piston of the master cylinder.
- the vehicle state (vehicle state amount) other than the hydraulic pressure such as the displacement amount of the vehicle may be used.
- the description has been given by taking as an example the case where the configuration is such that the calculation is performed (and the retention completion condition is determined based on the change amount ⁇ ).
- the present invention is not limited to this.
- the hydraulic pressure value before or after the energization suspension may be referred to (the holding completion condition is determined based on the hydraulic pressure value before or after the energization suspension). May be).
- the difference ⁇ between the maximum hydraulic pressure and the minimum hydraulic pressure in the judgment section during the suspension of energization may be used as the variation ⁇ .
- the apply completion current threshold value I ⁇ i I is constant regardless of the hydraulic pressure (for example, when the hydraulic pressure is 0 1 ⁇ /1 3, it is required by the electric motor 78).
- a thrust suppressing effect can be obtained even at the time of life.
- the holding completion condition is determined when the power supply is temporarily stopped during application, and when the holding completion condition is satisfied, the braking force
- the temporary stop of the power supply corresponds to the temporary stop of the power supply during the application, that is, the temporary stop of the power supply between the start of the application and the completion of the apply.
- reapplying may be performed, if necessary, after the application including the temporary stop of the power supply is completed.
- re-apply may be performed.
- the time from the completion of application to the re-apply does not correspond to the stop time at apply.
- the rear wheel side disk brake 6 is a hydraulic disk brake with an electric parking brake function
- the front wheel side disk brake 5 is a hydraulic disk brake without an electric parking brake function.
- the rear wheel side disk brake 6 is a hydraulic disk brake without an electric parking brake function
- the front wheel side disk brake 5 is a hydraulic disk brake with an electric parking brake function.
- both the front wheel side disc brake 5 and the rear wheel side disc brake 6 may be hydraulic disc brakes with an electric parking brake function.
- the brakes of at least a pair of left and right wheels of the vehicle wheels can be configured by the electric parking brake.
- the hydraulic disc brake is used as the hydraulic braking device, that is, the rear wheel side disc brake 6 is described as an example.
- the hydraulic braking device may use various hydraulic braking devices such as a hydraulic drum brake.
- the present invention is not limited to this, and various types of electric brake devices (electric brake mechanism, electric parking mechanism) such as a configuration including an electric motor and a ratchet mechanism may be used. That is, a hydraulic disc brake with an electric parking brake function, a hydraulic drum brake with an electric parking brake function, a drum-in disc brake with a drum type electric parking brake on the disc brake, and an electric motor pulling the cable.
- various electric parking brake devices including a hydraulic braking device and an electric braking device, such as a structure for holding the parking brake, can be adopted.
- each embodiment is an exemplification, and that the configurations shown in different embodiments can be partially replaced or combined.
- a first mode is a brake system mounted on a vehicle, wherein a hydraulic braking device that propels a piston by hydraulic pressure to press a braking member against a braked member, and a thrust transmitted from an electric motor.
- a control device that resumes the power supply to the electric motor after temporarily stopping the power supply to the motor, and completes the holding of the braking force when the holding completion condition for completing the holding of the braking force is satisfied.
- the control device determines the holding completion condition based on a change in a vehicle state of the vehicle when the power supply is temporarily stopped.
- the holding completion condition for completing the holding of the braking force is determined based on the change in the vehicle state.
- the holding of the braking force can be completed under the holding completion condition corresponding to the change in the vehicle state. In this case, suspend the power supply ⁇ 2020/175 179 43 ⁇ (:171? 2020 /005742
- the influence (error) due to the delay of the vehicle state information for example, hydraulic pressure information
- the holding can be completed with an appropriate braking force according to (the change of) the vehicle state at that time. ..
- the excess or deficiency (excess, insufficiency) of the thrust force due to the change in the vehicle state when the braking force is held based on the driving of the electric motor.
- the control device supplies electric power to the electric motor according to the hydraulic pressure applied to the piston when starting to maintain the braking force. Change the current threshold for a temporary stop.
- the power supply to the electric motor can be temporarily stopped at an appropriate current threshold value according to the hydraulic pressure. That is, the power supply can be temporarily stopped before the thrust becomes excessive. Then, when it is necessary to restart the power supply based on the change in the vehicle state when the vehicle is temporarily stopped, it is possible to suppress the thrust shortage by restarting the power supply.
- the vehicle state is a hydraulic pressure applied to the piston
- the control device changes the hydraulic pressure applied to the piston.
- the holding completion condition is determined by. According to the third aspect, it is possible to complete the holding of the braking force under the holding completion condition corresponding to the change in the hydraulic pressure.
- the control device controls the power supply time after the power supply is restarted as the amount of change in the hydraulic pressure during the temporary stop of the power supply is larger.
- the holding completion condition is determined so that According to the fourth mode, for example, the more the hydraulic pressure changes to the pressure reducing side (the greater the pressure reducing amount), the longer the power supply time after the restart of the power supply is suppressed, thereby suppressing the thrust shortage. it can. In this case, in order to prevent the thrust from becoming excessive, even if the power supply is temporarily stopped when the thrust is low, it is possible to suppress the shortage of the thrust when the holding of the braking force is completed.
- a fifth aspect is a brake control device mounted on a vehicle, in which a piston is propelled by hydraulic pressure or thrust transmitted from an electric motor to cover a braking member. ⁇ 2020/175 179 44 ⁇ (:171? 2020 /005742
- control unit that controls the electric motor in the brake mechanism that presses the braking member, the control unit drives the electric motor according to a control command that holds the braking force of the brake mechanism, and thrust is generated in the piston.
- the control unit drives the electric motor according to a control command that holds the braking force of the brake mechanism, and thrust is generated in the piston.
- the holding completion condition for completing the holding of the braking force is satisfied.
- the holding completion condition is determined based on the change in the vehicle state of the vehicle. According to the fifth aspect, it is possible to suppress the excess or deficiency (excess, insufficiency) of the thrust force due to the change of the vehicle state when the braking force is held based on the driving of the electric motor.
- the control unit acquires the hydraulic pressure applied to the brake mechanism when starting to hold the braking force, and adds the hydraulic pressure to the acquired hydraulic pressure. Accordingly, a current threshold value for temporarily stopping the power supply to the electric motor is set. According to the sixth aspect, the power supply to the electric motor can be temporarily stopped at an appropriate current threshold value according to the hydraulic pressure.
- the control unit acquires the hydraulic pressure applied to the piston as the vehicle state, and holds the hydraulic pressure based on a change in the hydraulic pressure. Set completion conditions. According to the seventh aspect, the holding of the braking force can be completed under the holding completion condition corresponding to the change of the hydraulic pressure.
- the control unit controls the electric power after the power supply is restarted as the amount of change in the hydraulic pressure during the temporary stop of the power supply is larger.
- the holding completion condition is set so that the supply time becomes longer. According to the eighth aspect, it is possible to suppress the thrust shortage when the holding of the braking force is completed.
- a ninth aspect is a brake control method for controlling the electric motor in a brake mechanism for propelling a piston by hydraulic pressure or thrust transmitted from the electric motor to press the braking member against the braked member, A step of starting current supply to the electric motor in response to a control command for holding the braking force of the brake mechanism; and temporarily supplying electric power to the electric motor during a current increase when thrust is generated in the piston. Stop the power supply to the electric motor temporarily. ⁇ 2020/175 179 45 ⁇ (:171? 2020 /005742
- the brake control method acquires the hydraulic pressure applied to the brake mechanism at the time of starting the current supply to the electric motor, and the acquisition The method further includes the step of setting a current threshold value for temporarily stopping the power supply to the electric motor according to the hydraulic pressure.
- the power supply to the electric motor can be temporarily stopped at an appropriate current threshold value according to the hydraulic pressure.
- the hydraulic pressure applied to the piston is acquired as the vehicle state, and the hydraulic pressure The holding completion condition is set based on the change.
- the holding of the braking force can be completed under the holding completion condition corresponding to the change of the hydraulic pressure.
- the above holding completion conditions are set so that the power supply time after the supply is resumed becomes longer. According to the 12th aspect, it is possible to suppress the shortage of the thrust force when the holding of the braking force is completed.
- the brake control device for controlling the electric motor in the brake mechanism for propelling the piston by the hydraulic pressure or the thrust transmitted from the electric motor to press the braking member against the braked member is executed. And a step of starting current supply to the electric motor in response to a control command for holding the braking force of the brake mechanism, wherein thrust is generated in the viston. ⁇ 2020/175 179 46 ⁇ (:171? 2020/005742
- the brake control program acquires the hydraulic pressure applied to the brake mechanism when starting the current supply to the electric motor, The step of setting a current threshold value for temporarily stopping the power supply to the electric motor according to the acquired hydraulic pressure is further executed. According to the fourteenth aspect, the power supply to the electric motor can be temporarily stopped at an appropriate current threshold value according to the hydraulic pressure.
- the hydraulic pressure applied to the piston is acquired as the vehicle state, and The holding completion condition is set based on the change.
- the holding of the braking force can be completed under the holding completion condition corresponding to the change of the hydraulic pressure.
- the above retention completion conditions are set so that the power supply time after the supply is resumed becomes longer. According to the sixteenth aspect, it is possible to prevent the thrust from being insufficient when the holding of the braking force is completed.
- part of the configuration of one embodiment can be replaced with the configuration of another embodiment, and the configuration of one embodiment can be added to the configuration of another embodiment. Further, it is possible to add/delete/replace other configurations with respect to a part of the configuration of each embodiment.
Landscapes
- Engineering & Computer Science (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Regulating Braking Force (AREA)
- Braking Systems And Boosters (AREA)
Abstract
パーキングブレーキ制御装置は、電動モータへの電力供給を一時的に停止させたあと、一時停止時間経過後に、必要に応じて、電動モータへの電力供給を再開する。そして、パーキングブレーキ制御装置は、制動力の保持を完了させる保持完了条件が成立したときに制動力の保持(アプライ)を完了させる。この場合に、パーキングブレーキ制御装置は、電力供給が一時的に停止されているときに、車両状態の変化に基づき、保持完了条件を決定する。保持完了条件は、車両状態として、ピストンに付与されている液圧の変化により決定される。
Description
\¥0 2020/175179 1 ?<:17 2020 /005742 明 細 書
発明の名称 :
ブレ _キシステム、 ブレ _キ制御装置、 ブレ _キ制御方法およびブレ _キ 制御プログラム
技術分野
[0001 ] 本発明は、 自動車等の車両に制動力を付与するブレーキシステム、 ブレー キ制御装置、 ブレーキ制御方法およびブレーキ制御プログラムに関する。 背景技術
[0002] 自動車等の車両には、 各車輪側の液圧ブレーキ (液圧制動装置) に向けて 液圧 (ブレーキ液圧) を供給することにより、 車両に制動力を付与するブレ —キシステムが搭載されている。 ここで、 液圧ブレーキは、 例えばディスク ブレーキであれば、 キヤリバのシリンダ内に外部から液圧を供給することに より、 ピストンを介してブレーキパッ ド (制動部材) をディスクロータ (被 制動部材) に押圧して制動力を発生させる。
[0003] このようなディスクブレーキとして、 例えば、 車両走行時に液圧に基づい て制動力を発生させるだけでなく、 車両の停車、 駐車時、 必要に応じて走行 時に、 電動モータ (電動機) の駆動 (回転) に基づいて制動力を発生させる 電動パーキングブレーキ機能付きの液圧式ディスクブレーキが知られている (特許文献 1) 。
先行技術文献
特許文献
[0004] 特許文献 1 :特開 2 0 1 5 - 4 7 9 4 5号公報 (特許第 6227333号公報)
発明の概要
発明が解決しようとする課題
[0005] 従来技術の場合、 パーキングブレーキのアプライ (制動付与) のときに、 車両状態の変化 (例えば、 液圧の変動) に伴って、 電動モータの駆動に基づ
〇 2020/175179 2 卩(:171? 2020 /005742
く推力が過剰 (過大) になる可能性がある。
課題を解決するための手段
[0006] 本発明の目的は、 アプライのとき (即ち、 電動モータの駆動に基づいて制 動力を保持するとき) に、 車両状態の変化 (例えば、 液圧の変動) に伴って 推力が過剰または不足することを抑制できるブレーキシステム、 ブレーキ制 御装置、 ブレーキ制御方法およびブレーキ制御プログラムを提供することに ある。
[0007] 本発明の一実施形態による車両に搭載されるブレーキシステムは、 液圧に よってピストンを推進して制動部材を被制動部材に押圧する液圧制動装置と 、 電動機から伝達される推力によって前記ピストンを推進して前記制動部材 を前記被制動部材に押圧し、 制動力を保持する電動ブレーキ装置と、 制動力 を保持する場合に、 前記ビストンに推力が発生する区間において前記電動機 への電力供給を一時的に停止させたあとに前記電動機への電力供給を再開し 、 制動力の保持を完了させる保持完了条件が成立したときに制動力の保持を 完了させる制御装置と、 を備え、 前記制御装置は、 前記電力供給が一時的に 停止されているときに、 前記車両の車両状態の変化に基づき、 前記保持完了 条件を決定する。
[0008] また、 本発明の一実施形態による車両に搭載されるブレーキ制御装置は、 液圧または電動機から伝達される推力によってピストンを推進して制動部材 を被制動部材に押圧するブレーキ機構における前記電動機を制御する制御部 を有し、 前記制御部は、 前記ブレーキ機構の制動力を保持する制御指令に応 じて前記電動機を駆動し、 前記ピストンに推力が発生している電流上昇の際 に、 前記電動機への電力供給を一時的に停止させたあとに前記電動機への電 力供給を再開し、 制動力の保持を完了させる保持完了条件が成立したときに 制動力の保持を完了させ、 前記電動機への電力供給を一時的に停止している ときに、 前記車両の車両状態の変化に基づき、 前記保持完了条件を決定する
[0009] また、 本発明の一実施形態によるブレーキ制御方法は、 液圧または電動機
〇 2020/175179 3 卩(:171? 2020 /005742
から伝達される推力によってピストンを推進して制動部材を被制動部材に押 圧するブレーキ機構における前記電動機を制御する方法であって、 前記ブレ _キ機構の制動力を保持する制御指令に応じて前記電動機への電流供給を開 始するステップと、 前記ピストンに推力が発生している電流上昇の際に、 前 記電動機への電力供給を一時的に停止させるステップと、 前記電動機への電 力供給を一時的に停止しているときに、 前記ブレーキ機構が搭載された車両 の車両状態の変化に基づき、 制動力の保持を完了させる保持完了条件を設定 するステップと、 前記電動機への電力供給を一時的に停止させた後、 前記電 動機への電力供給を再開するステップと、 前記保持完了条件が成立したとき に制動力の保持を完了させるステップと、 を含む。
[0010] また、 本発明の一実施形態によるブレーキ制御プログラムは、 液圧または 電動機から伝達される推力によってピストンを推進して制動部材を被制動部 材に押圧するブレーキ機構における前記電動機を制御するブレーキ制御装置 に実行させるプログラムであって、 前記ブレーキ機構の制動力を保持する制 御指令に応じて前記電動機への電流供給を開始するステップと、 前記ピスト ンに推力が発生している電流上昇の際に、 前記電動機への電力供給を一時的 に停止させるステップと、 前記電動機への電力供給を一時的に停止している ときに、 前記ブレーキ機構が搭載された車両の車両状態の変化に基づき、 制 動力の保持を完了させる保持完了条件を設定するステップと、 前記電動機へ の電力供給を一時的に停止させた後、 前記電動機への電力供給を再開するス テップと、 前記保持完了条件が成立したときに制動力の保持を完了させるス テップと、 を実行する。
[001 1 ] 本発明の一実施形態によれば、 電動機の駆動に基づいて制動力を保持する とき (アプライのとき) に、 車両状態の変化 (例えば、 液圧の変動) に伴っ て推力が過剰または不足することを抑制できる。
図面の簡単な説明
[0012] [図 1 ]第 1の実施形態によるブレーキシステムが搭載された車両の概念図。
[図 2]図 1中の後輪側に設けられた電動パーキングブレーキ機能付のディスク
〇 2020/175179 4 卩(:171? 2020 /005742
ブレーキを拡大して示す縦断面図。
[図 3]図 1中のパーキングブレーキ制御装置を後輪側ディスクブレーキ等と共 に示すブロック図。
[図 4]図 1中のパーキングブレーキ制御装置による制御処理を示す流れ図。
[図 5]図 4中の 「八」 、 「巳」 に続く処理を示す流れ図。
[図 6]図 5中の 3 9の 「△?判定処理」 を示す流れ図。
[図 7]液圧 とアプライー時停止電流閾値 I 8リ 3㊀との関係の一例を示す 特性線図。
[図 8]液圧の変化量△ と再通電時間 1
 との関係の一例を示す特性線図。 [図 9]第 1の実施形態によるモータ電流丨、 液圧 の時間変化の一例を示す特 性線図。
[図 10]第 2の実施形態による制御処理 (図 4中の 「八」 、 「巳」 に続く処理 ) を示す流れ図。
[図 1 1]図 1 0中の 3 2 1の 「△?判定処理」 を示す流れ図。
[図 12]第 2の実施の形態によるモータ電流 I、 液圧 の時間変化の一例を示 す特性線図。
[図 13]キヤリバ液圧真値に対する制御認識値の遅延による液圧誤差を示す説 明図 (時間変化の特性線図) 。
発明を実施するための形態
[0013] 以下、 実施形態によるブレーキシステムおよびブレーキ制御装置を、 4輪 自動車に搭載した場合を例に挙げ、 添付図面に従って説明する。 なお、 図 4 、 図 5、 図 6、 図 1 0、 図 1 1 に示す流れ図の各ステップは、 それぞれ 「3 」 という表記を用いる (例えば、 ステップ 1 = 「3 1」 とする) 。
[0014] 図 1ないし図 9は、 第 1の実施形態を示している。 図 1 において、 車両の ボディを構成する車体 1の下側 (路面側) には、 例えば左右の前輪 2 ( !_
, [¾) と左右の後輪 3 ([¾ !_ ,
 とからなる合計 4個の車輪が設けら れている。 車輪 (各前輪 2、 各後輪 3) は、 車体 1 と共に車両を構成してい る。 車両には、 制動力を付与するためのブレーキシステムが搭載されている
〇 2020/175179 5 卩(:171? 2020 /005742
。 以下、 車両のブレーキシステムについて説明する。
[0015] 前輪 2および後輪 3には、 それぞれの車輪 (各前輪 2、 各後輪 3) と共に 回転する被制動部材 (回転部材) としてのディスクロータ 4が設けられてい る。 前輪 2用のディスクロータ 4は、 液圧式のディスクブレーキである前輪 側ディスクブレーキ 5により制動力が付与される。 後輪 3用のディスクロー 夕 4は、 電動パーキングブレーキ機能付の液圧式のディスクブレーキである 後輪側ディスクプレーキ 6により制動力が付与される。
[0016] 左右の後輪 3に対応してそれぞれ設けられた一対 (一組) の後輪側ディス クプレーキ 6は、 液圧によりブレーキパッ ド 6〇 (図 2参照) をディスクロ —夕 4に押圧して制動力を付与する液圧式のブレーキ機構である。 図 2に示 すように、 後輪側ディスクブレーキ 6は、 例えば、 キャリアと呼ばれる取付 部材 6 と、 ホイルシリンダとしてのキャリバ 6巳と、 制動部材 (摩擦部材 、 摩擦パッ ド) としての一対のブレーキパッ ド 6(3と、 押圧部材としてのピ ストン 6 0とを備えている。 この場合、 キヤリパ 6巳とピストン 6 0は、 液 圧によってビストン 6 0を推進してブレーキパッ ド 6〇をディスクロータ 4 に押圧するシリンダ機構 (液圧制動装置) を構成している。
[0017] 取付部材 6 は、 車両の非回転部に固定され、 ディスクロータ 4の外周側 を跨いで形成されている。 キャリパ 6巳は、 取付部材 6八にディスクロータ 4の軸方向への移動を可能に設けられている。 キャリバ 6巳は、 シリンダ本 体部 6巳 1 と、 爪部 6巳 2と、 これらを接続するブリッジ部 6巳 3とを含ん で構成されている。 シリンダ本体部 6巳 1 には、 シリンダ (シリンダ穴) 6 巳 4が設けられており、 シリンダ 6巳 4内にはピストン 6 0が揷嵌されてい る。 ブレーキパッ ド 6〇は、 取付部材 6八に移動可能に取付けられ、 ディス クロータ 4に当接可能に配置されている。 ピストン 6 0は、 ブレーキパッ ド 6〇をディスクロータ 4に押圧する。
[0018] ここで、 キャリバ 6巳は、 ブレーキペダル 9の操作等に基づいてシリンダ
6巳4内に液圧 (ブレーキ液圧) が供給 (付加) されることにより、 ブレー キパッ ド 6〇をピストン 6 0で推進する。 このとき、 ブレーキパッ ド 6〇は
〇 2020/175179 6 卩(:171? 2020 /005742
、 キヤリパ 6巳の爪部 6巳 2とピストン 6 0とによりディスクロータ 4の両 面に押圧される。 これにより、 ディスクロータ 4と共に回転する後輪 3に制 動力が付与される。
[0019] さらに、 後輪側ディスクブレーキ 6は、 電動アクチユエータ 7と回転直動 機構 8とを備えている。 電動アクチユエータ 7は、 電動機としての電動モー 夕 7 と、 該電動モータ 7 の回転を減速する減速機 (図示せず) 等を含ん で構成されている。 電動モータ 7八は、 ピストン 6 0を推進するための推進 源 (駆動源) となるものである。 回転直動機構 8は、 ブレーキパッ ド 6〇の 押圧力を保持する保持機構 (押圧部材保持機構) を構成している。
[0020] この場合、 回転直動機構 8は、 電動モータ 7八の回転をピストン 6 0の軸 方向の変位 (直動変位) に変換すると共に該ピストン 6 0を推進する回転直 動部材 8 を含んで構成されている。 回転直動部材 8 は、 例えば、 雄ねじ が形成された棒状体からなるねじ部材 8 1 と、 雌ねじ穴が内周側に形成さ れた推進部材となる直動部材 8 2とにより構成されている。 回転直動機構 8は、 電動モータ 7八の回転をビストン 6口の軸方向の変位に変換すると共 に、 電動モータ 7八により推進したピストン 6 0を保持する。 即ち、 回転直 動機構 8は、 電動モータ 7八によりピストン 6 0に推力を与え、 該ピストン 6 0によりブレーキパッ ド 6〇を推進してディスクロータ 4を押圧し、 該ピ ストン 6口の推力を保持する。
[0021 ] このように、 後輪側ディスクブレーキ 6は、 回転直動機構 8および電動モ —夕 7八を備えている。 回転直動機構 8および電動モータ 7八は、 電動ブレ —キ機構 (電動ブレーキ装置) を構成している。 電動ブレーキ機構は、 電動 モータ 7 の回転力を減速機と回転直動機構 8とを介して推力に変換し、 ブ レーキパッ ド 6(3を押圧するピストン 6 0に推力を作用させて制動力の保持 または解除をする。 即ち、 電動ブレーキ機構は、 電動モータ 7八で駆動され る回転直動機構 8により推進されるビストン 6 0が、 ブレーキパッ ド 6〇を ディスクロータ 4に押圧し、 電動モータ 7八の停止によりブレーキパッ ド 6 〇を押圧位置で保持する。
〇 2020/175179 7 卩(:171? 2020 /005742
[0022] 電動ブレーキ機構 (電動ブレーキ装置) を構成する回転直動機構 8および 電動モータ 7八は、 シリンダ機構 (液圧制動装置) を構成するキャリバ 6巳 およびピストン 6 0と、 後述のパーキングブレーキ制御装置 2 4と共に、 ブ レーキシステムを構成している。 電動ブレーキ機構 (電動ブレーキ装置) は 、 電動モータ 7八から伝達される推力によってピストン 6 0を推進してブレ —キパッ ド 6(3をディスクロータ 4に押圧し、 制動力を保持する。
[0023] 後輪側ディスクブレーキ 6は、 ブレーキペダル 9の操作等に基づいて発生 するブレーキ液圧によりピストン 6 0を推進させ、 ブレーキパッ ド 6〇でデ ィスクロータ 4を押圧することにより、 車輪 (後輪 3) 延いては車両に制動 力を付与する。 これに加えて、 後輪側ディスクブレーキ 6は、 後述するよう に、 パーキングブレーキスイッチ 2 3からの信号等に基づく作動要求に応じ て、 電動モータ 7八により回転直動機構 8を介してピストン 6 0を推進させ 、 車両に制動力 (パーキングブレーキ、 必要に応じて補助ブレーキ) を付与 する。
[0024] 即ち、 後輪側ディスクブレーキ 6は、 電動モータ 7八を駆動し、 回転直動 部材 8八によりビストン 6 0を推進することにより、 ブレーキパッ ド 6〇を ディスクロータ 4に押圧して保持する。 この場合、 後輪側ディスクブレーキ 6は、 パーキングブレーキ (駐車ブレーキ) を付与するためのアプライ要求 となるパーキングブレーキ要求信号 (アプライ要求信号) に応じて、 ピスト ン 6 0を電動モータ 7八で推進して車両の制動を保持することが可能となっ ている。 これと共に、 後輪側ディスクプレーキ 6は、 ブレーキペダル 9の操 作に応じて、 液圧源 (後述のマスタシリンダ 1 2、 必要に応じて液圧供給装 置 1 6) からの液圧供給により車両の制動が可能となっている。
[0025] このように、 後輪側ディスクプレーキ 6は、 電動モータ 7八によりディス クロータ 4にブレーキパッ ド 6〇を押圧し該ブレーキパッ ド 6〇の押圧力を 保持する回転直動機構 8を有し、 かつ、 電動モータ 7八による押圧とは別に 付加される液圧によりディスクロータ 4にブレーキパッ ド 6(3を押圧可能に 構成されている。
〇 2020/175179 8 卩(:171? 2020 /005742
[0026] 一方、 左右の前輪 2に対応してそれぞれ設けられた一対 (一組) の前輪側 ディスクブレーキ 5は、 パーキングブレーキの動作に関連する機構を除いて 、 後輪側ディスクブレーキ 6とほぼ同様に構成されている。 即ち、 図 1 に示 すように、 前輪側ディスクブレーキ 5は、 取付部材 (図示せず) 、 キヤリバ 5八、 ブレーキパッ ド (図示せず) 、 ピストン 5巳等を備えているが、 パー キングブレーキの作動、 解除を行うための電動アクチュエータ 7 (電動モー 夕 7八) 、 回転直動機構 8等を備えていない。 しかし、 前輪側ディスクブレ —キ 5は、 ブレーキペダル 9の操作等に基づいて発生する液圧によりピスト ン 5巳を推進させ、 車輪 (前輪 2) 延いては車両に制動力を付与する点で、 後輪側ディスクブレーキ 6と同様である。 即ち、 前輪側ディスクブレーキ 5 は、 液圧によりブレーキパッ ドをディスクロータ 4に押圧して制動力を付与 する液圧式のブレーキ機構 (液圧ブレーキ) である。
[0027] なお、 前輪側ディスクブレーキ 5は、 後輪側ディスクブレーキ 6と同様に 、 電動パーキングブレーキ機能付のディスクブレーキとしてもよい。 また、 実施形態では、 電動パーキングブレーキ装置として、 電動パーキング機構を 備えた液圧式のディスクブレーキ 6を用いている。 しかし、 これに限定され ず、 電動パーキングブレーキ装置は、 例えば、 電動パーキング機構を備えた 液圧式のドラムブレーキ、 電動ドラム式のパーキング機構を備えた液圧式の ディスクプレーキ、 電動モータでケーブルを引っ張ることによりパーキング ブレーキをアプライ作動させるケーブルブラー式の電動パーキング機構を備 えた液圧式のディスクブレーキまたはドラムブレーキ等を用いてもよい。 即 ち、 電動パーキングブレーキ装置は、 電動モータ (電動アクチュエータ) の 駆動に基づいて摩擦部材 (パッ ド、 シュー) を回転部材 (ロータ、 ドラム) に押圧 (推進) し、 その押圧力の保持と解除とを行うことができる電動パー キング機構を備えた構成であれば、 各種の電動パーキングブレーキ装置を用 いることができる。
[0028] 車体 1のフロントボード側には、 ブレーキペダル 9が設けられている。 ブ レーキペダル 9は、 車両のブレーキ操作時に運転者 (ドライバ) によって踏
〇 2020/175179 9 卩(:171? 2020 /005742
込み操作される。 各ディスクブレーキ 5 , 6は、 ブレーキペダル 9の操作に 基づいて、 常用ブレーキ (サービスブレーキ) としての制動力の付与および 解除が行われる。 ブレーキペダル 9には、 ブレーキランプスイッチ、 ペダル スイッチ (ブレーキスイッチ) 、 ペダルストロークセンサ等のブレーキ操作 検出センサ (ブレーキセンサ) 1 0が設けられている。
[0029] ブレーキ操作検出センサ 1 0は、 ブレーキペダル 9の踏込み操作の有無、 または、 その操作量を検出し、 その検出信号を巳 3(3制御装置 1 7に出力す る。 ブレーキ操作検出センサ 1 0の検出信号は、 例えば、 車両データバス 2 0、 または、
 制御装置 1 7とパーキングブレーキ制御装置 2 4とを接 続する通信線 (図示せず) を介して伝送される (パーキングブレーキ制御装 置 2 4に出力される) 。
[0030] ブレーキペダル 9の踏込み操作は、 倍力装置 1 1 を介して、 油圧源 (液圧 源) として機能するマスタシリンダ 1 2に伝達される。 倍力装置 1 1は、 ブ レーキペダル 9とマスタシリンダ 1 2との間に設けられた負圧ブースタ (気 圧倍力装置) または電動ブースタ (電動倍力装置) として構成されている。 倍力装置 1 1は、 ブレーキペダル 9の踏込み操作時に、 踏力を増力してマス タシリンダ 1 2に伝える。
[0031 ] このとき、 マスタシリンダ 1 2は、 マスタリザーバ 1 3から供給 (補充) されるブレーキ液により液圧を発生させる。 マスタリザーバ 1 3は、 ブレー キ液が収容された作動液タンクとなるものである。 ブレーキペダル 9により 液圧を発生する機構は、 上記の構成に限られるものではなく、 ブレーキぺダ ル 9の操作に応じて液圧を発生する機構、 例えば、 ブレーキバイワイヤ方式 の機構等であってもよい。
[0032] マスタシリンダ 1 2内に発生した液圧は、 例えば一対のシリンダ側液圧配 管 1 4 , 1 4巳を介して、 液圧供給装置 1 6 (以下、 £ 3 0 1 6という) に送られる。 巳
 1 6は、 各ディスクプレーキ 5 , 6とマスタシリンダ 1 2との間に配置されている。 巳3〇 1 6は、 マスタシリンダ 1 2からシリン ダ側液圧配管 1 4 , 1 4巳を介して出力される液圧を、 ブレーキ側配管部
〇 2020/175179 10 卩(:171? 2020 /005742
1 5八, 1 5巳, 1 50, 1 50を介して各ディスクブレーキ 5, 6に供給 する。 即ち、 巳3〇 1 6は、 ブレーキペダル 9の操作に応じた液圧 (ブレー キ液圧) を、 各車輪 (各前輪 2、 各後輪 3) に設けられたディスクブレーキ 5, 6 (キヤリバ 5八, 6巳) へ供給するものである。 これにより、 車輪 ( 各前輪 2、 各後輪 3) のそれぞれに対して相互に独立して制動力を付与する ことができる。
[0033] ここで、 £301 6は、 液圧ブレーキ (前輪側ディスクブレーキ 5、 後輪 側ディスクブレーキ 6) の液圧を制御する液圧制御装置である。 このために 、 £301 6は、 複数の制御弁と、 ブレーキ液圧を加圧する液圧ポンプと、 該液圧ポンプを駆動する電動モータと、 余剰のブレーキ液を一時的に貯留す る液圧制御用リザーバ (いずれも図示せず) とを含んで構成されている。 巳 301 6の各制御弁および電動モータは、 巳3(3制御装置 1 7と接続されて おり、 巳3〇 1 6は、 巳 3〇制御装置 1 7を含んで構成されている。
[0034] 巳 3〇 1 6の各制御弁の開閉と電動モータの駆動は、 巳 3〇制御装置 1 7 により制御される。 即ち、 巳 3(3制御装置 1 7は、 巳3(31 6の制御を行う 巳 3〇用コントロールユニッ ト (巳 3〇用巳〇 II) である。 巳 3〇制御装置 1 7は、 マイクロコンピュータを含んで構成され、 £301 6 (の各制御弁 のソレノイ ド、 電動モータ) を電気的に駆動制御する。 この場合、 巳3〇制 御装置 1 7は、 例えば、 £301 6の液圧供給を制御し、 かつ、 £301 6 の故障を検出する演算回路、 電動モータおよび各制御弁を駆動する駆動回路 (いずれも図示せず) 等が内蔵されている。
[0035] 巳 3(3制御装置 1 7は、 £301 6の各制御弁 (のソレノイ ド) 、 液圧ポ ンプ用の電動モータを個別に駆動制御する。 これにより、 巳 3(3制御装置 1 7は、 ブレーキ側配管部 1 5八_ 1 50を通じて各ディスクブレーキ 5, 6 に供給するブレーキ液圧 (ホイールシリンダ液圧) を減圧、 保持、 増圧また は加圧する制御を、 それぞれのディスクブレーキ 5, 6毎に個別に行う。
[0036] この場合、 巳 3(3制御装置 1 7は、 巳 3(31 6を作動制御することにより 、 例えば以下の ( 1) _ (8) 等の制御を実行することができる。 (1) 車
〇 2020/175179 1 1 卩(:171? 2020 /005742
両の制動時に接地荷重等に応じて各車輪 2 , 3に適切に制動力を配分する制 動力配分制御。 (2) 制動時に各車輪 2 , 3の制動力を自動的に調整して各 車輪 2 , 3のロック (スリップ) を防止するアンチロックブレーキ制御 (液 圧八巳3制御) 。 (3) 走行中の各車輪 2 , 3の横滑りを検知してブレーキ ペダル 9の操作量に拘わらず各車輪 2 , 3に付与する制動力を適宜自動的に 制御しつつ、 アンダーステアおよび才ーバーステアを抑制して車両の挙動を 安定させる車両安定化制御。 (4) 坂道 (特に上り坂) において制動状態を 保持して発進を補助する坂道発進補助制御。 (5) 発進時等において各車輪 2 , 3の空転を防止するトラクシヨン制御。 (6) 先行車両に対して一定の 車間を保持する車両追従制御。 (7) 走行車線を保持する車線逸脱回避制御 。 (8) 車両進行方向の障害物との衡突を回避する障害物回避制御 (自動ブ レーキ制御、 衝突被害軽減ブレーキ制御) 。
[0037] £ 3 0 1 6は、 運転者のブレーキ操作による通常の動作時においては、 マ スタシリンダ 1 2で発生した液圧を、 ディスクプレーキ 5 , 6 (のキヤリバ 5八, 6巳) に直接供給する。 これに対し、 例えば、 アンチロックブレーキ 制御等を実行する場合は、 増圧用の制御弁を閉じてディスクブレーキ 5 , 6 の液圧を保持し、 ディスクブレーキ 5 , 6の液圧を減圧するときには、 減圧 用の制御弁を開いてディスクブレーキ 5 , 6の液圧を液圧制御用リザーパに 逃がすように排出する。
[0038] さらに、 車両走行時の安定化制御 (横滑り防止制御) 等を行うため、 ディ スクプレーキ 5 , 6に供給する液圧を増圧または加圧するときは、 供給用の 制御弁を閉弁した状態で電動モータにより液圧ボンプを作動させ、 該液圧ポ ンプから吐出したブレーキ液をディスクブレーキ 5 , 6に供給する。 このと き、 液圧ポンプの吸込み側には、 マスタシリンダ 1 2側からマスタリザーバ 1 3内のブレーキ液が供給される。
[0039] 巳 3〇制御装置 1 7には、 車両電源となるバッテリ 1 8 (ないしエンジン によって駆動されるジェネレータ) からの電力が、 電源ライン 1 9を通じて 給電される。 図 1 に示すように、 巳3(3制御装置 1 7は、 車両データバス 2
〇 2020/175179 12 卩(:171? 2020 /005742
0に接続されている。 なお、 巳3〇 1 6の代わりに、 公知の八巳 3ユニッ ト を用いることも可能である。 さらに、 巳3〇 1 6を設けずに (即ち、 省略し ) 、 マスタシリンダ 1 2とブレーキ側配管部 1 5八_ 1 5 0とを直接的に接 続することも可能である。
[0040] 車両データバス 2 0は、 車体 1 に搭載されたシリアル通信部としての〇八
 八「68 1|/\/0「1〇 を構成している。 車両に搭載された多数の電 子機器 (例えば、 巳 3〇制御装置 1 7、 パーキングブレーキ制御装置 2 4等 を含む各種の巳(3 II) は、 車両データバス 2 0により、 それぞれの間で車両 内の多重通信を行う。 この場合、 車両データバス 2 0に送られる車両情報と しては、 例えば、 ブレーキ操作検出センサ 1 0、 イグニッションスイッチ、 シートべルトセンサ、 ドアロックセンサ、 ドア開センサ、 着座センサ、 車速 センサ、 操舶角センサ、 アクセルセンサ (アクセル操作センサ) 、 スロッ ト ルセンサ、 エンジン回転センサ、 ステレオカメラ、 ミリ波レーダ、 勾配セン サ (傾斜センサ) 、 シフトセンサ (トランスミッションデータ) 、 加速度セ ンサ (◦センサ) 、 車輪速センサ、 車両のピッチ方向の動きを検知するピッ チセンサ等からの検出信号 (出力信号) による情報 (車両情報) が挙げられ る。
[0041 ] さらに、 車両データバス 2 0に送られる車両情報としては、 ホイルシリン ダ液圧 ( /〇液圧) を検出する /〇圧カセンサ 2 1、 マスタシリンダ液圧
2 2からの検出信号 (情報) も挙 げ
 圧カセンサ 2 2は、 例えば、 ブ レーキ操作検出センサ 1 〇と同様に、 巳 3〇制御装置 1 7に接続されている 。
 圧カセンサ 2 2の検出信号は、 /〇液圧 、 1\/1/〇液圧の情報として、 巳 3(3制御装置 1 7から車両データバス 2 0に送 られる。 車両に搭載された多数の電子機器 (各種の巳(3 11) は、 \/\//0液圧、 液圧を含む各種の車両情報を、 車両データバス 2 0を通じて入手するこ とができる。 なお、 /〇圧カセンサ 2 1および/または
 圧カセンサ 2 2は、 パーキングブレーキ制御装置 2 4に直接接続してもよい。
〇 2020/175179 13 卩(:171? 2020 /005742
[0042] 次に、 パーキングブレーキスイッチ 2 3およびパーキングブレーキ制御装 置 2 4について説明する。
[0043] 車体 1内には、 運転席 (図示せず) の近傍となる位置に、 電動パーキング ブレーキのスイッチとしてのパーキングブレーキスイッチ ( <巳_ 3 \^/)
2 3が設けられている。 パーキングブレーキスイッチ 2 3は、 運転者によっ て操作される操作指示部となるものである。 パーキングブレーキスイッチ 2 3は、 運転者の操作指示に応じたパーキングブレーキの作動要求 (保持要求 となるアプライ要求、 解除要求となるリリース要求) に対応する信号 (作動 要求信号) を、 パーキングブレーキ制御装置 2 4へ伝達する。 即ち、 パーキ ングブレーキスイッチ 2 3は、 電動モータ 7八の駆動 (回転) に基づいてピ ストン 6 0延いてはブレーキパッ ド 6〇をアプライ作動 (保持作動) または リリース作動 (解除作動) させるための作動要求信号 (保持要求信号となる アプライ要求信号、 解除要求信号となるリリース要求信号) を、 パーキング ブレーキ制御装置 2 4に出力する。 パーキングブレーキ制御装置 2 4は、 パ —キングブレーキ用コントロールユニッ ト (パーキングブレーキ用巳〇 II) である。
[0044] 運転者によりパーキングブレーキスイッチ 2 3が制動側 (アプライ側) に 操作されたとき、 即ち、 車両に制動力を付与するためのアプライ要求 (制動 保持要求) があったときは、 パーキングブレーキスイッチ 2 3からアプライ 要求信号 (パーキングブレーキ要求信号、 アプライ指令) が出力される。 こ の場合は、 後輪側ディスクブレーキ 6の電動モータ 7 に、 該電動モータ 7 八を制動側に回転させるための電力が、 パーキングブレーキ制御装置 2 4を 介して給電される。 このとき、 回転直動機構 8は、 電動モータ 7八の回転に 基づいてピストン 6 0をディスクロータ 4側に推進 (押圧) し、 推進したピ ストン 6 0を保持する。 これにより、 後輪側ディスクブレーキ 6は、 パーキ ングブレーキ (ないし補助ブレーキ) としての制動力が付与された状態、 即 ち、 アプライ状態 (制動保持状態) となる。
[0045] 一方、 運転者によりパーキングブレーキスイッチ 2 3が制動解除側 (リリ
〇 2020/175179 14 卩(:171? 2020 /005742
—ス側) に操作されたとき、 即ち、 車両の制動力を解除するためのリリース 要求 (制動解除要求) があったときは、 パーキングブレーキスイッチ 2 3か らリリース要求信号 (パーキングブレーキ解除要求信号、 リリース指令) が 出力される。 この場合は、 後輪側ディスクブレーキ 6の電動モータ 7八に、 該電動モータ 7八を制動側とは逆方向に回転させるための電力が、 パーキン グブレーキ制御装置 2 4を介して給電される。 このとき、 回転直動機構 8は 、 電動モータ 7八の回転によりピストン 6 0の保持を解除する (ピストン 6 口による押圧力を解除する) 。 これにより、 後輪側ディスクブレーキ 6は、 パーキングブレーキ (ないし補助ブレーキ) としての制動力の付与が解除さ れた状態、 即ち、 リリース状態 (制動解除状態) となる。
[0046] パーキングブレーキは、 例えば車両が所定時間停止したとき (例えば、 走 行中に減速に伴って、 車速センサの検出速度が 5
 未満の状態が所定 時間継続したときに停止と判断) 、 エンジンが停止したとき、 シフトレバー を (パーキング) に操作したとき、 ドアが開いたとき、 シートべルトが解 除されたとき等、 パーキングブレーキ制御装置 2 4でのパーキングブレーキ のアプライ判断ロジックによる自動的なアプライ要求に基づいて、 自動的に 付与 (才一トアプライ) することができる。 また、 パーキングブレーキは、 例えば車両が走行したとき (例えば、 停車から増速に伴って、 車速センサの 検出速度が 6 / 以上の状態が所定時間継続したときに走行と判断) 、 アクセルペダルが操作されたとき、 クラッチペダルが操作されたとき、 シフ トレバーが 、 1\]以外に操作されたとき等、 パーキングブレーキ制御装置 2 4でのパーキングブレーキのリリース判断ロジックによる自動的なリリース 要求に基づいて、 自動的に解除 (才一トリリース) することができる。 才一 トアプライ、 才一トリリースは、 パ _キングブレ _キスイッチ 2 3が故障し たときに、 自動的に制動力の付与または解除を行うスイッチ故障時補助機能 として構成することができる。
[0047] さらに、 車両の走行時にパーキングブレーキスイッチ 2 3の操作があった 場合、 より具体的には、 走行中に緊急的にパーキングブレーキを補助ブレー
〇 2020/175179 15 卩(:171? 2020 /005742
キとして用いる等の動的パーキングブレーキ (動的アプライ) の要求があっ た場合は、 例えば、 パーキングブレーキスイッチ 2 3の操作に応じて巳
 1 6による制動力の付与と解除を行うようにすることができる。 この場合は 、 例えば、 パーキングブレーキ制御装置 2 4は、 パーキングブレーキスイッ チ 2 3の操作に応じた制動指令 (例えば、 液圧要求信号、 目標液圧信号) を 、 車両データバス 2 0または前記通信線を介して、 巳 3(3制御装置 1 7に出 力する。 これにより、 巳3〇 1 6は、 パーキングブレーキ制御装置 2 4から 制動指令に基づいて、 パーキングブレーキスイッチ 2 3が制動側に操作され ている間 (制動側への操作が継続している間) 液圧による制動力を付与し、 その操作が終了すると液圧による制動力の付与を解除する。
[0048] 一方、 車両の走行時にパーキングブレーキスイッチ 2 3の操作があった場 合に、 £ 3 0 1 6による制動力の付与と解除に代えて、 例えば、 後輪側ディ スクプレーキ 6の電動モータ 7八の駆動による制動力の付与と解除を行うよ うにすることができる。 この場合は、 例えば、 パーキングブレーキ制御装置 2 4は、 パーキングブレーキスイッチ 2 3が制動側に操作されている間 (制 動側への操作が継続している間) 制動力を付与し、 その操作が終了すると制 動力の付与を解除する。 このとき、 パーキングブレーキ制御装置 2 4は、 車 輪 (各後輪 3) の状態、 即ち、 車輪がロック (スリップ) するか否かに応じ て、 自動的に制動力の付与と解除 ( 巳 3制御) を行う構成とすることがで きる。
[0049] 制御装置 (ブレーキ制御装置) としてのパーキングブレーキ制御装置 2 4 は、 後輪側ディスクブレーキ 6 (液圧制動装置、 電動ブレーキ装置) と共に 、 ブレーキシステムを構成している。 パーキングブレーキ制御装置 2 4は、 電動モータ 7八の駆動を制御する。 即ち、 パーキングブレーキ制御装置 2 4 は、 後輪側ディスクブレーキ 6における電動モータ 7八の駆動を制御する制 御部を有している。 このために、 図 3に示すように、 パーキングブレーキ制 御装置 2 4は、 マイクロコンピュータ等によって構成される演算回路 (〇 II) 2 5およびメモリ 2 6を有している。 パーキングブレーキ制御装置 2 4
〇 2020/175179 16 卩(:171? 2020 /005742
には、 バッテリ 1 8 (ないしエンジンによって駆動されるジェネレータ) か らの電力が電源ライン 1 9を通じて給電される。
[0050] パーキングブレーキ制御装置 2 4は、 後輪側ディスクブレーキ 6 , 6の電 動モータ 7 , 7 の駆動を制御し、 車両の駐車、 停車時 (必要に応じて走 行時) に制動力 (パーキングブレーキ、 補助ブレーキ) を発生させる。 即ち 、 パーキングブレーキ制御装置 2 4は、 左右の電動モータ 7八, 7八を駆動 することにより、 ディスクプレーキ 6 , 6をパーキングブレーキ (必要に応 じて補助ブレーキ) として作動 (アプライ · リリース) させる。 このために 、 パーキングブレーキ制御装置 2 4は、 入力側がパーキングブレーキスイッ チ 2 3に接続され、 出力側は各ディスクブレーキ 6 , 6の電動モータ 7八,
7八に接続されている。 そして、 パーキングブレーキ制御装置 2 4は、 運転 者の操作 (パーキングブレーキスイッチ 2 3の操作) の検出、 電動モータ 7 八, 7八の駆動可否判定、 電動モータ 7八, 7八の停止の判定等を行うため の演算回路 2 5と、 電動モータ 7八, 7八を制御するためのモータ駆動回路 2 8 , 2 8とを内蔵している。
[0051 ] パーキングブレーキ制御装置 2 4は、 運転者のパーキングブレーキスイッ チ 2 3の操作による作動要求 (アプライ要求、 リリース要求) 、 パーキング ブレーキのアプライ · リリースの判断ロジックによる作動要求、 八巳3制御 による作動要求に基づいて、 左右の電動モータ 7 , 7 を駆動し、 左右の ディスクブレーキ 6 , 6のアプライ (保持) またはリリース (解除) を行う 。 このとき、 後輪側ディスクブレーキ 6では、 各電動モータ 7 の駆動に基 づいて、 回転直動機構 8によるピストン 6 0およびブレーキパッ ド 6〇の保 持または解除が行われる。 このように、 パーキングブレーキ制御装置 2 4は 、 ピストン 6 0 (延いてはブレーキパッ ド 6〇) の保持作動 (アプライ) ま たは解除作動 (リリース) のための作動要求信号に応じて、 ピストン 6 0 ( 延いてはブレーキパッ ド 6〇) を推進するべく電動モータ 7八を駆動制御す る。
[0052] 図 3に示すように、 パーキングブレーキ制御装置 2 4の演算回路 2 5には
〇 2020/175179 17 卩(:171? 2020 /005742
、 記憶部としてのメモリ 2 6に加えて、 パーキングブレーキスイッチ 2 3、 車両データバス 2 0、 電圧センサ部 2 7、 モータ駆動回路 2 8、 電流センサ 部 2 9等が接続されている。 車両データバス 2 0からは、 パーキングブレー キの制御 (作動) に必要な車両の各種状態量、 即ち、 各種車両情報を取得す ることができる。 また、 パーキングブレーキ制御装置 2 4は、 車両データパ ス 2 0または前記通信線を介して、 巳 3(3制御装置 1 7を含む各種巳(3 IIに 情報や指令を出力することができる。
[0053] なお、 車両データバス 2 0から取得する車両情報は、 その情報を検出する センサをパーキングブレーキ制御装置 2 4 (の演算回路 2 5) に直接的に接 続することにより取得する構成としてもよい。 また、 パーキングブレーキ制 御装置 2 4の演算回路 2 5は、 車両データバス 2 0に接続された他の制御装 置 (例えば巳 3(3制御装置 1 7) から前述の判断ロジックや 巳 3制御に基 づく作動要求が入力されるように構成してもよい。 この場合は、 前述の判断 ロジックによるパーキングブレーキのアプライ · リリースの判定や八巳 3の 制御を、 パーキングブレーキ制御装置 2 4に代えて、 他の制御装置、 例えば 巳 3(3制御装置 1 7で行う構成とすることができる。 即ち、 巳 3(3制御装置 1 7にパーキングブレーキ制御装置 2 4の制御内容を統合することが可能で ある。
[0054] パーキングブレーキ制御装置 2 4は、 例えばフラッシュメモリ、


[0055] なお、 実施形態では、 パーキングブレーキ制御装置 2 4を巳 3〇制御装置
〇 2020/175179 18 卩(:171? 2020 /005742
1 7と別体としたが、 パーキングブレーキ制御装置 2 4と巳 3 <3制御装置 1 7とを一体に (即ち、 1個の制動用制御装置により一体に) 構成してもよい 。 この場合、 巳3(3制御装置 1 7内にパーキングブレーキ制御装置 2 4の機 能が統合され、 後輪側ディスクブレーキ 6 , 6やパーキングスイッチ 2 3が 巳 3(3制御装置 1 7に接続される。 また、 巳 3(3制御装置 1 7には、 後述の 図 4ないし図 6に示されるブレーキ制御プログラムが格納され、 巳 3〇制御 装置 1 7がブレーキ制御装置として、 電動ブレーキ装置に対するブレーキ制 御を実行することになる。 パーキングブレーキ制御装置 2 4は、 左右で 2つ の後輪側ディスクブレーキ 6 , 6を制御するようにしているが、 左右の後輪 側ディスクプレーキ 6 , 6毎に設けるようにしてもよく、 この場合には、 そ れそれのパーキングブレーキ制御装置 2 4を後輪側ディスクブレーキ 6に一 体的に設けることもできる。
[0056] 図 3に示すように、 パーキングブレーキ制御装置 2 4には、 電源ライン 1
9からの電圧を検出する電圧センサ部 2 7、 左右の電動モータ 7八, 7八を それぞれ駆動する左右のモータ駆動回路 2 8 , 2 8、 左右の電動モータ 7八 , 7八のそれぞれのモータ電流を検出する左右の電流センサ部 2 9 , 2 9等 が内蔵されている。 これら電圧センサ部 2 7、 モータ駆動回路 2 8、 電流セ ンサ部 2 9は、 それぞれ演算回路 2 5に接続されている。 これにより、 パー キングブレーキ制御装置 2 4の演算回路 2 5では、 駐車ブレーキのアプライ またはリリースを行うときに、 電流センサ部 2 9により検出される電動モー 夕 7八の電流値 (の変化) に基づいて、 電動モータ 7八の駆動の停止の判定 (アプライ完了の判定、 リリース完了の判定) 等を行うことができる。 なお 、 図示の例では、 電圧センサ部 2 7は、 電源電圧を検出 (計測) する構成と しているが、 例えば、 電圧センサ部 (電圧センサ) は、 電動モータ 7八, 7 八の端子間電圧を左右独立して計測する構成としてもよい。
[0057] ところで、 前述の特許文献 1のブレーキシステムは、 液圧に応じて電流閾 値を補正することにより、 電動モータの駆動に基づいて発生する推力が過剰 になることを抑制する。 即ち、 電動パーキングブレーキは、 キヤリバに液圧
〇 2020/175179 19 卩(:171? 2020 /005742
が付加されている状態でアプライをすると、 ビストンが電動モータによる推 力のみならず液圧によっても推進され、 液圧解除後のピストン推力 (以下、 保持推力という) が過剰になる可能性がある。 これを抑制するために、 電動 モータの駆動に基づいて発生する推力を、 液圧に応じて調整することにより 、 この推力を抑制する制御が有効である。 しかし、 例えば、 液圧情報の遅延 により、 制御で用いる液圧 (制御認識液圧) が実際のキヤリバ内の液圧 (実 キヤリバ液圧、 キヤリバ液圧真値) と乖離している場合に、 制御認識液圧に 基づいて電動モータによる推力を制御すると、 保持推力が不足する可能性が ある。 これに対して、 特許文献 1では、 液圧に対する電動モータの推力制御 量に予めマージンを設けて推力を高めに発生させることで、 保持推力が不足 することを抑制している。 即ち、 特許文献 1では、 電流閾値を補正するとき に、 液圧の動特性を考慮したマージンを設けることにより、 推力の不足を抑 制している。
[0058] より詳しくは、 図 1 3に示すように、 キヤリバ液圧真値に対して制御認識 液圧は、 例えば〇 (車両データバス 2 0) 経由で受信 (取得) すること による通信遅れ、 フィルタによる遅延に伴って、 液圧が変動したときに誤差 (液圧誤差) が発生する可能性がある。 特許文献 1 によれば、 液圧の急減圧 による液圧誤差を予め考慮し、 液圧に対する電動モータによる推力の制御量 にマージンを設けることで、 保持推力の不足を防いでいる。
[0059] この技術によれば、 急減圧時の推力の不足を抑制できると考えられる。 し かし、 例えば、 液圧変動がない場合には、 マージン (オフセッ ト) 分の推力 を不必要に発生させることとなり、 推力抑制効果が低くなる可能性がある。 _方で、 液圧の急増圧時には、 液圧に対する推力抑制量が不足し、 保持推力 が過大となる可能性がある。 また、 アプライ時には、 電動モータによりビス トンが推進されて液室 (キヤリパ内の液圧室) が拡大するため、 必然的に液 圧の変動が発生する。 このため、 アプライ時に液圧が変動しても、 推力の過 不足 (過剰、 不足) を抑制できることが望まれている。
[0060] そこで、 第 1の実施形態では、 液圧に応じて電動モータ 7八の駆動による
〇 2020/175179 20 卩(:171? 2020 /005742
推力を調整する際に、 液圧を精度よく検出し、 過剰な保持推力を抑制できる ように、 次の構成を採用している。 即ち、 第 1の実施形態では、 アプライの 途中、 即ち、 アプライ時の推力発生中に、 電動モータ 7八に対する通電を一 時停止する。 このとき、 通電一時停止中を含む範囲での液圧変化から、 液圧 の遅延によるキヤリバ液圧真値と制御認識液圧の誤差を推定する。 そして、 この誤差を考慮した液圧の変化に基づいて、 通電一時停止後の電動モータ 7 八の再駆動の要否 (増し締めの要否) 、 電動モータ 7 の再駆動量 (増し締 め量) を決定する。 この場合、 例えば、 液圧の変化が減圧のときは、 推力減 少となるので、 増し締め量 (再通電時間) を増大させる。 これに対して、 液 圧の変化が増圧のときは、 増し締め量 (再通電時間) を減少させる、 または 、 増し締めしない (再通電時間を〇とする) 。 これにより、 液圧情報の遅延 に起因する推力のばらつきを低減することで、 過剰な保持推力を抑制するこ とができる。 即ち、 電動モータ 7八による推力を液圧に応じて調整 (抑制) するときに、 液圧を精度よく検出し (液圧誤差を回避できるように検出し)
、 液圧変動による保持推力が過剰となることを抑制できる。 この結果、 キヤ リバ 6巳 (液圧制動装置) 、 電動モータ 7八 (電動ブレーキ装置) の小型、 軽量化を図ることができる。
[0061 ] このために、 第 1の実施形態では、 パーキングブレーキ制御装置 2 4 (の 制御部) は、 制動力を保持する場合に、 ピストン 6 0に推力が発生する区間 において、 電動モータ 7八への電力供給を一時的に停止させる。 即ち、 パー キングブレーキ制御装置 2 4 (の制御部) は、 制動力を保持するパーキング ブレーキ要求信号 (制御指令) に応じて、 電動モータ 7八を駆動し、 ピスト ン 6口に推力が発生している電流上昇の際に、 電動モータ 7八への電力供給 を一時的に停止させる。 この場合に、 一時停止時間は、 液圧情報の遅延時間 より長い時間 (かつ、 例えば、 1〜 2秒より短い時間) に設定されている。 なお、 一時停止時間経過後は、 車両状態の変化 (液圧の変化) に応じて、 通 電を再開してからアプライを終了 (完了) する場合と、 通電を再開せずにア プライを終了 (完了) する場合とがある。 以下の説明では、 通電を再開しな
〇 2020/175179 21 卩(:171? 2020 /005742
い場合も含めて、 一時停止とする。 例えば、 一時停止時間経過するまで、 よ り具体的には、 保持完了条件である通電再開後の電力供給時間 (再通電時間 「 6) が決定するまでは、 通電を再開しない場合も含めて、 一時停止に相 当するものとする。
[0062] パーキングブレーキ制御装置 2 4 (の制御部) は、 パーキングブレーキス イッチ 2 3または前述のパーキングブレーキの作動判断ロジックによるパー キングブレーキ要求信号 (制御指令) に応じて、 電動モータ 7八の駆動を開 始する。 この場合、 パーキングブレーキ制御装置 2 4は、 先ず、 電動モータ 7八の駆動を一時停止する電流閾値 (アプライー時停止電流閾値丨 3リ 3 6) に達するまで電動モータ 7八を駆動する。 電流閾値 (アプライー時停止 電流閾値 I 3リ 3㊀) は、 電動モータ 7八の駆動によりピストン 6 0に推 力が発生する区間で、 電動モータ 7八の電力供給を停止できるように設定さ れている。 これにより、 パーキングブレーキ制御装置 2 4は、 ピストン 6 0 に推力が発生する区間において電動モータ 7八への電力供給を一時的に停止 することができる。
[0063] ここで、 パーキングブレーキ制御装置 2 4は、 電動モータ 7八を駆動して いるときおよび一時停止しているときに、 後輪側デイスクプレーキ 6の液圧 情報、 即ち、 キヤリバ 5八内の液圧 (の変化) を検出ないし推定 (算出) する。 なお、 キヤリバ 5八内の液圧 としては、 /〇圧カセンサ 2 1 により 検出される /〇液圧 /〇、 1\/1/〇圧カセンサ 2 2により検出される 1\/1/〇 液圧 1\/1/〇、 1\/1/〇液圧 1\/1/〇から算出される /〇液圧 /〇等、 液 圧 に直接的に対応する液圧 ( /〇、 1\/1/〇 を用いることができ る他、 液圧 を推定できる情報 (状態量) 3を用いることができる。 実施の 形態では、 液圧 として、 1\/1/〇圧カセンサ 2 2により検出される 1\/1/〇液圧 1\/1/〇を用いる。
[0064] パーキングブレーキ制御装置 2 4は、 パーキングブレーキ要求信号により 電動モータ 7八を駆動し始めたあと、 キヤリバ 5八内の液圧

に応じて電動モータ 7八の駆動を一時停止する電流閾値 (アプライ
〇 2020/175179 22 卩(:171? 2020 /005742
一時停止電流閾値丨 p a u s e) を決定する。 具体的には、 電動モータ 7 A を駆動しているときに、 図 7に示す液圧 Pとアプライー時停止電流閾値丨 p a u s eとの関係 (実線の特性線 3 1) に基づいて、 アプライー時停止電流 閾値 I p a u s eを、 そのとき (現在の制御周期) の液圧 Pに対応する値に 決定する。 そして、 パーキングブレーキ制御装置 24は、 電動モータ 7 Aの 電流値 (モータ電流丨) が、 そのときの液圧 Pに対応したアプライー時停止 電流閾値丨 p a u s eになった (超えた) ときに、 電動モータ 7 Aの駆動を 一時停止する (制動一時保持状態とする) 。
[0065] このように、 パーキングブレーキ制御装置 24は、 制動力の保持を開始す るときのビストン 5 Bに付与されている液圧 Pに応じて、 電動モータ 7 Aへ の電力供給を一時的に停止させるための電流閾値であるアプライー時停止電 流閾値丨 p a u s e (以下、 一時停止電流閾値丨 p a u s eともいう) を変 更する。 即ち、 パーキングブレーキ制御装置 24 (の制御部) は、 制動力の 保持を開始するときに、 後輪側デイスクプレーキ 6へ付加される液圧 Pを取 得し、 当該取得した液圧 Pに応じて電動モータ 7 Aへの電力供給を一時的に 停止させるためのアプライー時停止電流閾値丨 p a u s eを設定する。 図 7 に示すように、 一時停止電流閾値丨 p a u s e 、 液圧 Pが小さくなる程大 きな値として設定されている。 このため、 液圧 Pが小さいときは、 大きな一 時停止電流閾値丨 p a u s eで電動モータ 7 Aの駆動を一時的に停止させる ことができる。 一方、 液圧 Pが大きいときは、 小さな一時停止電流閾値丨 p a u s eで電動モータ 7 Aの駆動を一時的に停止させることができる。 これ により、 電動モータ 7 Aの駆動中の液圧 Pに応じた適切な一時停止電流閾値 I p a u s eで、 電動モータ 7 Aの駆動を一時的に停止させることができる
[0066] この場合、 一時停止電流閾値丨 p a u s e 、 電動モータ 7 Aの駆動に基 づいてピストン 6 Dに推力が発生する区間であることを判定できるように、 その最小値丨 pm i nは、 電動モータ 7 Aが空走している区間 (直動部材 8 A 2がビストン 6 Dに当接する前の区間) の電流値 (例えば、 1〜 3 A程度
〇 2020/175179 23 卩(:171? 2020 /005742
) よりも高い値 (例えば、 5八程度) に設定されている。 また、 液圧 が 0 IV! 3のときの一時停止電流閾値丨 0は、 例えば、 液圧 が 0 IV! 3の状 態のまま電動モータ 7八の駆動のみによって付与すべき最終的な推力 (車両 の停止を維持できる推力) に対応する電流値と同等以下に設定することがで きる。
[0067] パーキングブレーキ制御装置 2 4 (の制御部) は、 電動モータ 7八への電 力供給を一時的に停止させたあと、 一時停止時間経過後に、 必要に応じて、 電動モータ 7八への電力供給を再開する。 そして、 パーキングブレーキ制御 装置 2 4は、 制動力の保持を完了させる保持完了条件が成立したときに制動 力の保持 (アプライ) を完了させる。 この場合に、 パーキングブレーキ制御 装置 2 4 (の制御部) は、 電力供給が一時的に停止されているときに、 車両 状態の変化に基づき、 保持完了条件を決定する。 即ち、 第 1の実施形態では 、 電力供給を一時的に停止しているときの車両状態の変化、 より具体的には 、 一時停止中および/または一時停止前後の車両状態の変化に基づいて、 電 力供給を一時停止した後の保持完了条件を決定する。 保持完了条件は、 車両 状態として、 ピストン 6口に付与されている液圧の変化により決定される。 即ち、 パーキングブレーキ制御装置 2 4 (の制御部) は、 車両状態として、 ピストン 6口に付与されている液圧の変化を取得し、 当該液圧の変化に基づ いて、 電力供給を一時停止した後の保持完了条件を決定する。
[0068] 例えば、 保持完了条件は、 電力供給が一時的に停止されている間の液圧の 変化量が大きいほど、 電力供給の再開後の電力供給時間を長くする。 即ち、 パーキングブレーキ制御装置 2 4 (の制御部) は、 電力供給が一時的に停止 されている間の液圧の変化量が大きいほど電力供給の再開後の電力供給時間 を長くなるように、 保持完了条件を設定する。 より具体的には、 電力供給が 一時的に停止されている間の液圧の低下量 (減圧量) が大きいほど、 電力供 給の再開後の電力供給時間を長くする。 _方、 電力供給が一時的に停止され ている間の液圧の上昇量 (増圧量) が大きいほど、 電力供給の再開後の電力 供給時間を短く、 または、 〇にする (再開しない) 。 パーキングブレーキ制
〇 2020/175179 24 卩(:171? 2020 /005742
御装置 2 4は、 車両状態 (液圧) の変化に基づいて決定した保持完了条件を 成立させるベく、 必要に応じて電動モータ 7 の駆動を再開し、 決定した保 持完了条件で電動モータ 7八を停止する。
[0069] ここで、 液圧の変化が減圧 (急減圧) の場合を考える。 この場合、 パーキ ングブレーキ制御装置 2 4が認識する液圧値の誤差、 即ち、 遅延に伴う制御 認識値の液圧誤差は、 制御認識値が実際の液圧値である真値よりも遅れて低 下することにより発生する。 このため、 液圧の変化が減圧のときに、 制御認 識値は、 真値よりも大きくなる。 そこで、 この場合には、 パーキングブレー キ制御装置 2 4は、 減圧時の制御認識液圧の遅延により発生する液圧誤差 ( 制御認識値 >真値) を通電一時停止中に検出し、 後述の図 8に基づいて通電 再開後の電力供給時間 (再通電時間 「 6) を決定する。 具体的には、 通電 再開後の電力供給時間 (再通電時間
 を長くする (増し締め量を増加 させる) ことで、 推力の不足を回避する。 これにより、 電動モータ 7八の推 力抑制量に対するマージンを低減することが可能となり、 保持推力の抑制効 果を高めることができる。
[0070] _方、 液圧の変化が増圧 (急増圧) の場合を考える。 この場合、 遅延に伴 う制御認識値の液圧誤差は、 制御認識値が真値よりも遅れて増加することに より発生する。 このため、 液圧の変化が増圧のときに、 制御認識値は、 真値 よりも小さくなる。 そこで、 この場合には、 パーキングブレーキ制御装置 2 4は、 増圧時の制御認識液圧の遅延により発生する液圧誤差 (制御認識値 < 真値) を通電一時停止中に検出し、 後述の図 8に基づいて通電再開後の電力 供給時間 (再通電時間 1 「 6) を決定する。 具体的には、 通電再開後の電力 供給時間 (再通電時間 「 6) を短く (増し締め量を減少) 、 または、 0に する (増し締めしない) ことで、 推力が過剰になることを回避する。 これに より、 保持推力の抑制効果を高めることができる。
[0071 ] さらに、 パーキングブレーキ制御装置 2 4は、 通電を一時停止した状態の 液圧 を用いて液圧変動を検知する。 このため、 電動モータ 7八によりビス トン 6 0が推進する (液圧室が拡大する) ことによる液圧変動がない状況で
〇 2020/175179 25 卩(:171? 2020 /005742
液圧を監視することができる。 これにより、 液圧検出精度を向上でき、 この 面からも、 保持推力の抑制効果を高めることができる。 このようなパーキン グブレーキを作動 (アプライ) させるときのパーキングブレーキ制御装置 2 4による電動モータ 7八のアプライ制御 (図 4ないし図 6の制御処理) に関 しては、 後で詳しく述べる。
[0072] 第 1の実施形態による 4輪自動車のブレーキシステムは、 上述の如き構成 を有するもので、 次に、 その作動について説明する。
[0073] 車両の運転者がブレーキペダル 9を踏込み操作すると、 その踏力が倍力装 置 1 1 を介してマスタシリンダ 1 2に伝達され、 マスタシリンダ 1 2によっ てブレーキ液圧が発生する。 マスタシリンダ 1 2内で発生したブレーキ液圧 は、 シリンダ側液圧配管 1 4八, 1 4巳、 £ 3 0 1 6およびブレーキ側配管 部 1 5八, 1 5巳, 1 5 0 , 1 5 0を介して各ディスクブレーキ 5 , 6に供 給され、 左右の前輪 2と左右の後輪 3とにそれぞれ制動力が付与される。
[0074] この場合、 各ディスクプレーキ 5 , 6では、 キヤリパ 5八, 6巳内のブレ —キ液圧の上昇に従ってピストン 5巳, 6 0がブレーキパッ ド 6〇 (後輪 3 側のみ図示) に向けて摺動的に変位し、 ブレーキパッ ド 6〇がディスクロー 夕 4 , 4に押し付けられる。 これにより、 ブレーキ液圧に基づく制動力が付 与される。 一方、 ブレーキ操作が解除されたときには、 キヤリバ 5八, 6巳 内へのブレーキ液圧の供給が停止されることにより、 ピストン 5巳, 6 0が ディスクロータ 4 , 4から離れる (後退する) ように変位する。 これによっ て、 ブレーキパッ ド 6(3がディスクロータ 4 , 4から離間し、 車両は非制動 状態に戻される。
[0075] 次に、 車両の運転者がパーキングブレーキスイッチ 2 3を制動側 (アブラ イ側) に操作したときは、 パーキングブレーキ制御装置 2 4から左右の後輪 側ディスクブレーキ 6の電動モータ 7八に給電が行われ、 電動モータ 7八が 回転駆動される。 後輪側ディスクブレーキ 6では、 電動モータ 7 の回転運 動が回転直動機構 8により直線運動に変換され、 回転直動部材 8 によりピ ストン 6 0が推進する。 これにより、 ブレーキパッ ド 6〇によりディスクロ
〇 2020/175179 26 卩(:171? 2020 /005742
—夕 4が押圧される。 このとき、 回転直動機構 8 (直動部材 8 A 2) は、 例 えば、 螺合による摩擦力 (保持力) により制動状態を保持される。 これによ り、 後輪側ディスクブレーキ 6は、 パーキングブレーキとして作動 (アプラ イ) される。 即ち、 電動モータ 7 Aへの給電を停止した後にも、 回転直動機 構 8により、 ビストン 6 Dは制動位置に保持される。
[0076] 一方、 運転者がパーキングブレーキスイッチ 2 3を制動解除側 (リリース 側) に操作したときには、 パーキングブレーキ制御装置 2 4から電動モータ 7 Aに対してモータが逆転するように給電される。 この給電により、 電動モ —夕 7 Aがパーキングブレーキの作動時 (アプライ時) と逆方向に回転され る。 このとき、 回転直動機構 8による制動力の保持が解除され、 ピストン 6 Dがディスクロータ 4から離れる方向に変位することが可能になる。 これに より、 後輪側ディスクブレーキ 6は、 パーキングブレーキとしての作動が解 除 (リリース) される。
[0077] 次に、 パーキングブレーキ制御装置 2 4の演算回路 2 5で行われるアブラ イ制御処理について、 図 4ないし図 6を参照しつつ説明する。 なお、 図 5は 、 図 4に続く処理である。 図 6は、 図 5中の S 9の 「A P判定処理」 に対応 する。 図 4ないし図 6の制御処理は、 例えば、 パーキングブレーキ制御装置 2 4に通電している間、 所定の制御周期 (例えば、 1 O msec) で繰り返し実 行される。 なお、 これらの処理は、 電動モータ 7 Aを制御するブレーキ制御 方法であると共に、 ブレーキ制御プログラムとしてブレーキ制御装置である パーキングブレーキ制御装置 2 4により実行される。
[0078] E C U (E lect ron i c Cont ro l Un i t) であるパーキングブレーキ制御装置 2 4が起動すると、 図 4のアプライ制御処理が開始される。 パーキングブレー キ制御装置 2 4は、 処理ルーチンが開始されると、 S 1で、 アプライ作動中 フラグが〇 Nであるか否かを判定する。 アプライ作動中フラグは、 アプライ 作動中であるか否かを判定するための判定フラグである。 アプライ作動中フ ラグは、 アプライ作動中、 即ち、 電動モータ 7 Aの駆動の一時停止を含む、 アプライを開始してから完了するまでの間に〇 Nとなる。 具体的には、 後述
〇 2020/175179 27 卩(:171? 2020 /005742
の S 3の処理で〇 Nとなり、 S 1 5 (図 5) の処理で〇 F Fとなる。
[0079] S 1 T 「N〇」 、 即ち、 アプライ作動中フラグが〇 F Fであると判定され た場合は、 S 2に進む。 S 1で 「YES」 、 即ち、 アプライ作動中フラグが 〇 Nであると判定された場合は、 S4に進む。 S 2では、 アプライ指令 (制 御指令) があるか否かを判定する。 この S 2では、 パーキングブレーキスイ ツチ 23やパーキングブレーキのアプライ判断ロジツク等からアプライ指令 が出力されたか否かを判定する。 S 2で 「YES」 、 即ち、 アプライ指令あ りと判定された場合は、 S 3に進む。 一方、 S 2で 「N0」 、 即ち、 アブラ イ指令なしと判定された場合は、 リターンする。 即ち、 図 4の 「B」 、 図 5 の 「B」 、 図 5のリターンを介して図 4のスタートに戻り、 S 1以降の処理 を繰り返す。
[0080] S 3では、 アプライ作動中フラグを ONにする。 また、 電動モータ 7 Aを アプライ方向に駆動する。 S 3で、 アプライ作動中フラグを〇 Nにすると共 に、 電動モータ 7 Aのアプライ方向への駆動を開始したら、 S4に進む。 S 3は、 後輪側ディスクブレーキ 6の制動力を保持する制御指令 (アプライ指 令) に応じて電動モータ 7 Aへの電力供給を開始するステツプに相当する。 このとき、 即ち、 S 3では、 電動モータ 7 Aの駆動を開始したときに、 タイ マ (突入電流経過判定用タイマ) のカウントを開始する。 S4では、 突入電 流マスク時間が経過したか否かを判定する。 突入電流マスク時間は、 電動モ —夕 7 Aをアプライ方向に作動を開始してからの時間であり、 突入電流が十 分収束する時間を設定する。 S4で 「N0」 、 即ち、 突入電流経過判定用夕 イマによる経過時間が突入電流マスク時間を経過していないと判定された場 合は、 リターンする。 これは、 続く S 6でアプライー時停止電流閾値 I p a u s eを決定するときに、 突入電流の影響を受けにくくする、 即ち、 突入電 流により電流値がアプライー時停止電流閾値丨 p a u s eまたはアプライ完 了電流閾値丨 c u tを超えてアプライー時停止またはアプライ完了を誤検知 してしまうことを抑制するためである。 一方、 S4で 「YES」 、 即ち、 突 入電流マスク時間が経過したと判定された場合は、 S 5に進む。
〇 2020/175179 28 卩(:171? 2020 /005742
[0081 ] 3 5では、 アプライー時停止フラグが〇 1\1であるか否かを判定する。 アブ ライー時停止フラグは、 アプライ作動中に通電を一時停止したか否かを判定 するための判定フラグであり、 電動モータ 7八への電力供給を一時的に停止 すると〇1\1になる。 具体的には、 後述の 3 7の処理で〇1\1となり、 3 1 5の 処理で〇 となる。
[0082] 3 5で 「N 0」 、 即ち、 アプライー時停止フラグが〇 1\!でない (〇 で ある) と判定された場合は、 3 6に進む。 3 5で 「丫巳3」 、 即ち、 アブラ イー時停止フラグが〇1\1であると判定された場合は、 3 8に進む。 3 6では 、 モータ電流丨が一時停止電流閾値丨 8リ 3㊀を上回った (超えた) か否 かを判定する。 ここで、 一時停止電流閾値丨 3リ 3 6は、 図 7に示すマッ プ (特性線図) を用いて決定する。 即ち、 3 6では、 3 6に進んだときの液 圧値 、 具体的には、 〇 (車両データバス 2 0) 経由で受信 (取得) し た液圧
 圧カセンサ 2 2の 1\/1/〇液圧 1\/1/〇 から、 図 7に実線で 示す特性線 3 1 に基づいて、 一時停止電流閾値丨 3リ 3㊀を設定 (決定) する。 そして、 「3 6に進んだときの液圧 に対応する一時停止電流閾値 I 8リ 3㊀」 と 「現時点 (3 6に進んだとき) のモータ電流値丨」 とを比較 し、 モータ電流丨が一時停止電流閾値丨 3リ 3 6よりも大きいか否かを判 定する。 3 6は、 電動モータ 7 への電流供給を開始するときに、 後輪側デ ィスクプレーキ 6へ付加される液圧を取得し、 当該取得した液圧に応じて電 動モータ 7八への電力供給を一時的に停止させるための電流閾値を設定する ステップに相当する。
[0083] ここで、 図 7に示すように、 一時停止電流閾値丨 3リ 3 6は、 〇八1\1 ( 車両データバス 2 0) 経由で取得した液圧 (マスタシリンダ液圧) が高く なるほど、 低く設定している。 ただし、 無負荷状態での電流で一時停止を誤 判定しないように、 下限値丨 丨 n未満には抑制しない。 下限値丨 丨 nは 、 制動力 (推力) が発生する (直動部材 8八 2がピストン 6 0に当接して推 力が発生する) のが確実な電流値、 換言すれば、 電動モータ 7八の駆動によ りピストン 6 0に推力が発生するのが確実な電流値に対応している。 下限値
〇 2020/175179 29 卩(:171? 2020 /005742
丨 !11丨 は、 制動力が発生する前の空走期間の電流値 (空走電流丨 0、 例え ば 1 八~ 3八) よりも高い値 (例えば 5八程度) として設定されている。
[0084] また、 図 7では、 実線の特性線 3 1は、 誤差を考慮しない理想的な液圧 と一時停止電流閾値丨 3リ 3 6との関係である破線の特性線 3 2に対して 、 X軸方向に 〇分オフセッ トさせている。 即ち、 一時停止電流閾値丨 3 リ 3㊀の算出にオフセッ ト 0を持たせている。 このオフセッ ト 〇 (マー ジン) は、 「遅延以外の要因」 により液圧 に生じる推力減少方向の液圧誤 差 (液圧認識値が真値より大) よりも大きく設定している。 これにより、 「 遅延以外の要因」 による誤差によって推力が不足することを抑制している。 ここで、 「遅延」 は、 例えば、 車両データバス 2 0による通信遅れ、 液圧 の処理を行う電子機器 (コントロールユニッ ト : 巳 3〇制御装置 1 7、 パー キングブレーキ制御装置 2 4) の計算遅れ (処理遅れ) が挙げられる。 実施 の形態では、 オフセッ ト 〇は、 このような遅延を含まない、 「遅延以外の 要因」 による誤差、 例えば、
 圧カセンサ 2 2の不可避的な検出誤差 ( センサ誤差) による液圧誤差よりも大きく設定している。
[0085] 3 6で 「丫巳 3」 、 即ち、 モータ電流丨が _時停止電流閾値丨 8リ 3㊀ よりも大きいと判定された場合は、 3 7に進む。 3 6で 「N 0」 、 即ち、 モ —夕電流丨が一時停止電流閾値丨 3
 ㊀以下であると判定された場合は 、 リターンする。 3 7では、 アプライー時停止フラグを〇 1\!とし、 電動モー 夕 7八に対する通電を一時停止する。 3 7は、 ピストン 6 0に推力が発生し ている電流上昇の際に、 電動モータ 7 への電力供給を一時的に停止させる ステップに相当する。 また、 その時点 (3 7に進んだ時点、 図 9では時点 1) での〇 (車両データバス 2 0) 経由で取得した液圧

を液圧 1 として記憶する。 3 7または 3 5の 「丫巳 3」 に続く 3 8では、 アプライー時停止フラグが〇 1\1となってから予め設定したアプライ 一時停止時間が経過しているか否かを判定する。 3 8で 「丫巳3」 、 即ち、 アプライー時停止時間が経過していると判定された場合には、 図 4の 「八」
、 図 5の 「八」 を介して、 図 5の 3 9に進む。 3 8で 「N 0」 、 即ち、 アプ
〇 2020/175179 30 卩(:171? 2020 /005742
ライー時停止時間が経過していないと判定された場合には、 リターンする。 ここで、 アプライー時停止時間は、 液圧 の遅延時間より長い時間を設定し ている。 これにより、 続く 39の八 判定処理にて、 液圧 の遅延による誤 差発生を判定できるようにしている。
[0086] 39では、
 判定処理を行う。 3
 判定処理は、 図 5に示す処理 である。 3
 判定処理では、 通電一時停止中の液圧の変化量
 ( 2- 1) に基づいて、 通電再開後の電力供給時間 (再通電時間 1
 を決 定する。 即ち、 39では、 電力供給を一時停止しているときの液圧の変化量 △ に基づいて、 通電一時停止時間の経過後に再度通電を行うか否かを含む 再通電時間 1
 を決定する。 38で 「丫巳3」 と判定され 39、 即ち、 図 6の 39 _ 1 に進むと、 39- 1では、 再通電時間 1: 「 6が算出済みか否か を判定する。 39— 1で 「N0」 、 即ち、 再通電時間 I 「 6が算出されてい ないと判定された場合には、 39-2に進む。 39- 1で 「丫巳3」 、 即ち 、 再通電時間 「 6が算出済みと判定された場合には、 図 6のリターンを介 して図 5の 31 0に進む。 再通電時間 「 6は、 電力供給の再開後に電動モ —夕 7八に電力を供給する時間 (電力供給時間) である。
[0087] 39 _ 2では、 その時点 (39— 2に進んだ時点、 図 9では時点 1 2) で の〇 (車両データバス 20) 経由で受信した液圧

) を液圧 2として記憶する。 39-2では、 37で記憶した液圧 1 と 3 9 _ 2で記憶した 2の液圧差、 即ち、 液圧の変化量
 (= 2- 1) を 算出する。 ここで、 △?>0 ( 2> 1) のときは、 液圧 は増大中であ り、 △?<0 ( 2< 1) のときは、 液圧 は減少中である。 △? = 0の ときは、 液圧 が変化していない (液圧 が一定である) 。 39 _ 2で、 液 圧の変化量八 を算出したら、 39— 3に進む。
[0088] 39— 3では、 再通電時間 I
 を決定 (算出) する。 39— 3は、 電動 モータ 7八への電力供給を一時的に停止しているときに、 車両状態の変化に 基づき、 保持完了条件を設定するステップに相当する。 保持完了条件である 再通電時間 1
 は、 例えば、 図 8に示すマップ (特性線図) を用いて決定
〇 2020/175179 31 卩(:171? 2020 /005742
(算出) する。 即ち、 S 9— 3では、 図 8に示す再通電時間 t r eと変化量 △ Pとの関係 (実線の特性線 4 1) に基づいて、 直前の S 9-2で算出した 液圧の変化量△ Pから再通電時間 t r eを決定する。 ここで、 図 8に示すよ うに、 変化量 APが液圧変化閾値 APm a Xより小さいとき (増圧の変化が 小さいとき、 0のとき、 減圧の変化のとき) 、 再通電時間 t 「 6は0より大 きくなる。 この場合、 変化量△ Pが液圧変化閾値△ P m a Xに対して小さく なるほど (減圧側ほど) 、 再通電時間 t r eが長くなる (再通電による増し 締め量が増大する) 。 一方、 変化量△ Pが液圧変化閾値△ P m a x以上のと き (増圧の変化が大きいとき) 、 再通電時間 t r eは 0となる (再通電され ず、 増し締めされない) 。 これにより、 変化量 APが (減圧側に) 大きい程 、 再通電後の電力供給時間を長く している。 APm a xは、 例えば、 アプラ イー時停止電流閾値丨 p a u s eと変化量△ Pとの関係で、 通電一時停止後 に必要な再通電 (増し締め) を行うことができるように設定することができ る。 S 9— 3は、 車両状態として、 ピストン 6 Dに付与されている液圧の変 化を取得し、 当該液圧の変化に基づいて保持完了条件を設定するステップに 相当する。 また、 S 9— 3は、 電力供給が一時的に停止されている間の液圧 の変化量が大きいほど電力供給の再開後の電力供給時間を長くなるように、 保持完了条件を設定するステップに相当する。
[0089] S 9— 3に続く S 9— 4では、 S 9— 3で算出した再通電時間 t r eが 0 より大きい (t r e>0) か否かを判定する。 S 9— 4で 「YES」 、 即ち 、 再通電時間 t r eが 0よい大きいと判定された場合は、 再通電が必要な場 合に対応する。 この場合は、 図 6のリターンを介して図 5の S 1 0に進む。 これに対して、 S 9— 4で 「N0」 、 即ち、 再通電時間 t r eが 0である ( t r e = 0) と判定された場合は、 再通電が必要ない場合に対応する。 この 場合は、 S 9 - 5でアプライ完了フラグを〇 Nにしてから、 図 6のリターン を介して図 5の S 1 0に進む。
[0090] 図 5に示すように、 S 9に続く S 1 0では、 アプライ完了フラグが〇 Nで あるか否かを判定する。 S 1 0で 「YES」 、 即ち、 アプライ完了フラグが
\¥0 2020/175179 32 卩(:17 2020 /005742
〇1\1であると判定された場合には、 3 1 5に進む。 3 1 0で 「N 0」 、 即ち 、 アプライ完了フラグが〇1\1ではないと判定された場合には、 3 1 1 に進む
[0091 ] 3 1 1では、 一時停止していた電動モータ 7八が再通電中か否かを判定す る。 3 1 1で 「丫巳3」 、 即ち、 電動モータ 7八が再通電中であると判定さ れた場合には、 3 1 3に進む。 3 1 1で 「N 0」 、 即ち、 電動モータ 7八が 再通電中ではないと判定された場合には、 3 1 2に進む。 3 1 2では、 電動 モータ 7八に対する通電を再開し、 3 1 3に進む。 このとき、 即ち、 3 1 2 では、 通電を再開したときに、 タイマ (通電再開タイマ) のカウントを開始 する。 3 1 2は、 電動モータ 7八への電力供給を一時的に停止させた後、 電 動モータ 7八への電力供給を再開するステップに相当する。
[0092] 3 1 3では、 通電を再開してからの経過時間 (通電再開タイマのカウント 時間) が、 図 6の 3 9 _ 3で算出した再通電時間 I 「 6を超えたか否かを判 定する。 言い換えれば、 3 1 3では、 制動力の保持を完了 (電動モータ 7八 を停止) させるための保持完了条件、 より具体的には、 電力供給が一時的に 停止されているときに決定した保持完了条件が成立したか否かを判定する。
3 1 3で 「丫巳 3」 、 即ち、 電動モータ 7八に対する通電を再開してからの 時間 (通電再開タイマのカウント時間) が、 再通電時間 「 6を経過した ( 保持完了条件が成立した) と判定された場合には、 3 1 4に進む。 3 1 3で 「N 0」 、 即ち、 電動モータ 7八に対する通電を再開してからの時間 (通電 再開タイマのカウント時間) が、 再通電時間 「 6を超えていない (保持完 了条件が不成立) と判定された場合は、 リターンする。
[0093] 3 1 4では、 電動モータ 7八の再駆動 (再通電) を停止すべく、 アプライ 完了フラグを〇1\1にし、 3 1 5に進む。 3 1 5では、 各タイマ (突入電流経 過判定用タイマ、 通電再開タイマ) 、 フラグ (アプライ作動中フラグ、 アブ ライー時停止フラグ、 プライ完了フラグフラグ) をクリアする。 即ち、 各夕 イマを 0にすると共に各フラグを〇 にする。 また、 3 1 5では、 電動モ —夕 7八に対する通電を停止 (通電一時停止中も含めて完全に停止) する。
〇 2020/175179 33 卩(:171? 2020 /005742
即ち、 3 1 5では、 制動力の保持を完了 (アプライを完了) させ、 リターン する。 3 1 5は、 制動力の保持を完了させる保持完了条件が成立したときに 制動力の保持を完了させるステップに相当する。
[0094] 次に、 図 9は、 パーキングブレーキ制御装置 2 4により図 4ないし図 6に 示す処理を行ったときのタイムチヤート (アプライ時のモータ電流丨 と液圧 の時間変化) の一例を示している。 図 9では、 一定の液圧が付与された状 態で、 電動モータ 7八の駆動に基づいてピストン 6 0が推進することにより 液圧室が拡大し、 この液圧室の拡大に伴って液圧が低下する場合を示してい る。 なお、 例えば、 ブレーキペダル 9の操作等に基づき、 液圧 が変化 (低 下) する場合も同様に考えることができる。 また、 液圧 は、 パーキングブ レーキ制御装置 2 4が〇 (車両データバス 2 0) 経由で認識する液圧 ( 制御認識液圧) を示している。
[0095] 図 9に示すように、 パーキングブレーキ制御装置 2 4は、 アプライ指令が あると、 電動モータ 7八に電力を供給し、 電動モータ 7八をアプライ方向に 駆動する。 このとき、 電動モータ 7八は、 停止状態から駆動状態に移行する ため、 一度大きな突入電流が発生し、 その後低下して一定の値 (電流値丨 0 ) に維持される。 電流が一定 (電流値丨 0) のときは、 直動部材 8八 2がピ ストン 6口に当接する前の空走期間に対応する。 直動部材 8 2がピストン 6 0に当接すると、 モータ電流丨が上昇し始める。 ここからピストン 6 0に 推力が発生する区間が始まり、 ピストン 6 0への伝達推力の増大に伴って、 モータ 7八に供給される電流が上昇していく。 このとき、 ピストン 6 0の推 進による液圧室の拡大に伴って、 液圧 が低下する。 この場合、 パーキング ブレーキ制御装置 2 4が認識する液圧 は、 前述の遅延に伴って、 モータ電 流丨が上昇し始めたあとに低下し始める。
[0096] パーキングブレーキ制御装置 2 4は、 図 4の 3 6の処理により、 「そのと きの液圧 」 と 「図 7の特性線 3 1」 とに基づいて、 アプライ中に電動モー 夕 7八を一時的に停止するアプライー時停止電流閾値丨 3リ 3 6を設定す る。 時点 1で、 モータ電流丨が、 そのときの液圧 に応じたアプライー時
〇 2020/175179 34 卩(:171? 2020 /005742
停止電流閾値丨 3リ 3 6を上回ると、 電動モータ 7八への電力供給を停止 する。 これにより、 電動モータ 7八の回転が停止する。 このとき、 液圧 の 低下は、 直ちに停止せず、 遅延により、 時点 1 1 よりも遅れて停止する。 パ —キングブレーキ制御装置 2 4は、 アプライー時停止時間が経過した時点 I 2で、 図 6の 3 9 - 2および 3 9 - 3の処理により、 「電動モータ 7八を停 止したときの液圧 1 とアプライー時停止時間が経過したときの液圧 2と の差厶 (= ? 2 - 1) 」 と 「図 8の特性線 4 1」 とに基づいて、 再通電時 間 I
 (保持完了条件) を決定する。 パーキングブレーキ制御装置 2 4は 、 再通電時間 「 6が 0よりも大きいときは、 アプライー時停止時間が経過 した時点 2で、 電動モータ 7八に対する通電を再開する。 パーキングブレ —キ制御装置 2 4は、 通電を再開してから再通電時間 1
 6が経過すると、 電動モータ 7八に対する通電 (再通電) を停止し、 アプライ処理を終了する 。 なお、 再通電時間 「 6が 0のときは、 通電を再開しないことが保持完了 条件となるため、 アプライー時停止時間が経過した時点 2でアプライ処理 が終了する。 これにより、 電動モータ 7八の一時停止中 (より具体的には、 一時停止前後) の液圧の変化量八 (= 9 2 - 9 1) に基づいて、 通電の再開 の要否を含む再通電時間を決定し、 必要に応じて再通電することにより推力 の過不足を抑制できる。
[0097] 以上のように、 第 1の実施形態では、 電動モータ 7八への電力供給を一時 停止しているときに、 制動力の保持を完了させる保持完了条件 (再通電時間 「 6) を、 車両状態 (液圧 ) の変化に基づいて決定する。 これにより、 車両状態 (液圧 ) の変化に対応した保持完了条件 (再通電時間 1 「 6) で 、 制動力の保持を完了させることができる。 この場合に、 電力供給を一時停 止することにより、 車両状態の情報 (例えば、 液圧情報) の遅延による影響 (誤差) を抑制して、 そのときの車両状態 (の変化) に応じた適切な制動力 で保持を完了させることができる。 この結果、 電動モータ 7八の駆動に基づ いて制動力を保持するときの車両状態 (液圧 ) の変化に伴う推力の過不足 (過剰、 不足) を抑制することができる。
〇 2020/175179 35 卩(:171? 2020 /005742
[0098] 第 1の実施形態では、 液圧 に応じて電動モータ 7八への電力供給を一時 的に停止させるためのアプライー時停止電流閾値丨 3リ 3㊀を変更する。 このため、 電動モータ 7八への電力供給の一時停止を、 液圧 に応じた適切 なアプライー時停止電流閾値丨 3リ 3 6で行うことができる。 即ち、 推力 が過剰になる前に電力供給を一時停止できる。 そして、 一時停止していると きの車両状態 (液圧 ) の変化に基づき電力供給の再開が必要なときは、 電 力供給を再開することで、 推力が不足することを抑制できる。
[0099] 第 1の実施形態では、 制動力の保持を完了させる保持完了条件を液圧 の 変化により決定する。 このため、 液圧 の変化に対応した保持完了条件 (再 通電時間 I 「 6) で制動力の保持を完了させることができる。 しかも、 保持 完了条件 (再通電時間 「 6) は、 電力供給が一時的に停止されている間の 液圧 の変化量
 が大きいほど、 より具体的に、 液圧 が減圧側に大きく 変化するほど (減圧量が大きくなるほど) 、 電力供給の再開後の電力供給時 間である再通電時間 「 6を長く している。 このため、 推力が過剰になるこ とを抑制すべく、 推力が低い状態で電力供給を一時停止しても、 制動力の保 持を完了したときの推力の不足を抑制できる。
[0100] 次に、 図 1 0ないし図 1 2は、 第 2の実施形態を示している。 第 2の実施 形態の特徴は、 アプライ中に電力供給を一時的に停止しているときに、 「電 力供給を再開して所定の電流閾値に達してから電力供給を停止することによ りアプライを終了する」 か 「再開せずにアプライを終了する」 かを決定する ことにある。 なお、 第 2の実施形態では、 第 1の実施形態と同一の構成要素 に同 _の符号を付し、 その説明を省略する。
[0101 ] 第 2の実施形態も、 第 1の実施形態と同様に、 電力供給が一時的に停止さ れているときに、 車両状態 (液圧) の変化に基づき、 アプライを完了させる 保持完了条件を決定する。 前述の第 1の実施形態では、 アプライ中の通電一 時停止の前後の圧力差に基づいて、 通電一時停止後の再通電時間 1: 「 6 (保 持完了条件) を決定する。 これに対して、 第 2の実施形態では、 アプライ中 の通電一時停止前後の圧力差に基づいて、 通電一時停止後に通電再開をする
〇 2020/175179 36 卩(:171? 2020 /005742
か否かを決定する。 この場合、 保持完了条件として、 「電力供給を再開して アプライ完了電流閾値丨 〇リ Iに達したときに電力供給を停止することによ り保持完了とする」 か 「電力供給を再開せずに保持完了とする」 かを決定す る。
[0102] ここで、 第 2の実施形態では、 電力供給を一時的に停止するときに、 前述 の図 7に示したマップと同様のマップ (図示せず) に基づきアプライー時停 止電流閾値丨 3リ 3㊀を決定する。 この場合、 第 2の実施形態では、 オフ セッ ト 〇は、 液圧 に生じるセンサ誤差等の遅延以外の要因による推力減 少方向の液圧誤差 (液圧認識値が真値より大) だけでなく、 常用域で発生す る遅延による液圧誤差よりも大きく設定している。 即ち、 第 2の実施形態の オフセッ ト 0は、 第 1の実施の形態の図 7に示すオフセッ ト 0よりも大 きい値となっている。 このため、 第 2の実施形態での液圧 とアプライー時 停止電流閾値丨 8リ 3㊀との関係は、 例えば、 第 1の実施形態の図 7の特 性線 3 1 を全体として右側に平行移動した特性線として設定することができ る。 これにより、 増し締め頻度を下げつつ、 推力不足を抑制することができ る。 また、 例えば、 液圧 が 0 IV! 3のときの一時停止電流閾値丨 〇も、 図 7の特性線 3 1の一時停止電流閾値丨 0よりも大きくすることができる
[0103] また、 第 2の実施形態では、 電力供給が一時的に停止されているときに、 車両状態である液圧 の変化に基づき電力供給を再開すると決定した場合は 、 再開後に電動モータ 7八の電流値 (モータ電流丨) が、 アプライ完了電流 閾値丨 〇リ 1:になった (超えた) ときに、 電動モータ 7八の駆動を停止する 。 アプライ完了電流閾値丨 〇リ 1:は、 電力供給を再開したのちの電流閾値、 即ち、 再開した電力供給を停止してアプライ完了とする電流閾値である。 ア プライ完了電流閾値丨 〇リ 1:は、 例えば、 液圧 が 0 1\/1 3のときに電動モ —夕 7八の駆動によって必要な推力 (車両の停止を維持できる推力) を付与 することができる電流閾値丨 1113乂として設定することができる。 これにより、 遅延による液圧誤差発生時の推力不足を回避することができる。
〇 2020/175179 37 卩(:171? 2020 /005742
[0104] このような制御処理を行うために、 パーキングブレーキ制御装置 24のメ モリ 26には、 図 4、 図 1 0、 図 1 1 に示す処理フローを実行するための処 理プログラムが格納されている。 なお、 図 1 0は、 図 4に続く処理である。 図 1 1は、 図 1 0中の 32 1の 「△?判定処理」 に対応する。 図 4の制御処 理については、 第 1の実施形態で説明したため、 その説明を省略する。 また 、 図 1 0中の 31 0、 31 1、 31 2、 31 4, 31 5の処理は、 前述の図 5中の 31 0、 31 1、 31 2、 31 4, 31 5の処理と同様であり、 図 1 1中の 32 1 -2、 32 1 -4は、 図 6中の 39-2、 39-5の処理と同 様であるため、 その説明を省略する。
[0105] 38 (図 4) の 「丫巳 3」 に続く 32 1 (図 1 0) では、 △ 判定処理を 行う。 32 1の△ 判定処理は、 図 1 1 に示す処理である。 32 1の八 判 定処理では、 通電一時停止中の液圧の変化量△ (92 91) に基づいて、 通電一時停止時間の経過後に再通電を行うか否かを判定する。 具体的には、
38 (図 4) で 「丫巳 3」 と判定され図 1 0の 32 1、 即ち、 図 1 1の 32 1 — 1 に進むと、 32 1 - 1では、 変化量△ が算出済みか否かを判定する 。 32 1 — 1で 「丫巳3」 、 即ち、 変化量△ が算出済みであると判定され た場合には、 図 1 1のリターンを介して図 1 0の 31 0に進む。 32 1 - 1 で 「N0」 、 即ち、 変化量八 が算出済みでないと判定された場合には、 3 2 1 - 2を介して 32 1 -3に進む。
[0106] 32 1 _ 3では、 通電一時停止中の変化量

より小さい
 か否かを判定する。 なお、 液圧変化閾値△ 018 Xは、 液圧誤差マージンであるオフセツ ト 0より小さく設定する。 32 1 —3で 「丫巳3」 、 即ち、 変化量
 が液圧変化閾値

小さい
 と判定された場合には、 図 1 1のリターンを介 して図 1 0の 31 0に進む。 32 1 —3で 「N0」 、 即ち、 変化量
 圧変化閾値△ 3 X以上である
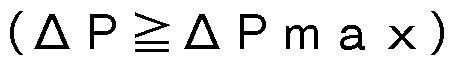 と判定された場合に は、 32 1 _ 4に進む。
[0107] ここで、 32 1 —3で 「丫巳 3」 、 即ち、 通電一時停止中の変化量△? (
〇 2020/175179 38 卩(:171? 2020 /005742
液圧変化) が液圧変化閾値△ 3 Xより小さいと判定された場合は、 液圧 誤差がマージン 〇を上回る可能性がある。 このため、 3 2 1 — 3では、 マ —ジン 0を上回るか否かを検出 (判定) し、 上回る場合にはこれ以降の処 理で通電を再開 (増し締め) する。 一方、 3 2 1 —3で 「N 0」 、 即ち、 通 電一時停止中の変化量△ (液圧変化) が液圧変化閾値△ P m a X以上であ ると判定された場合は、 3 2 1 - 4の処理でアプライ完了フラグを〇 1\1にし 、 これ以降の処理で通電が再開 (増し締め) されないようにする。 このよう に、 3 2 1 —3では、 アプライを終了 (完了) させる保持完了条件が決定さ れる。
[0108] 図 1 0の 3 2 2では、 通電再開後突入電流マスク時間が経過しているか否 かを判定する。 通電再開後突入電流マスク時間は、 3 1 2で通電を再開して からの時間であり、 通電再開の突入電流が十分収束する時間を設定する。 3 2 2で 「丫巳3」 、 即ち、 通電再開後突入電流マスク時間が経過していると 判定された場合には、 3 2 3に進む。 3 2 2で 「N 0」 、 即ち、 通電再開後 突入電流マスク時間が経過していないと判定された場合には、 リターンする
[0109] 3 2 3では、 モータ電流丨がアプライ完了電流閾値丨 〇リ を上回ってい る (丨 >丨 〇リ 1:) か否かを判定する。 即ち、 3 2 3では、 電力供給が一時 的に停止されているときに決定した保持完了条件が成立しているか否かを判 定する。 3 2 3で 「N 0」 、 即ち、 モータ電流丨がアプライ完了電流閾値 I 〇リ 1:以下 (丨 £ 丨 〇リ 1:) であると判定された場合には、 保持完了条件が 不成立であるため、 リターンする。 3 2 3で 「丫巳3」 、 即ち、 モータ電流 Iがアプライ完了電流閾値丨 〇リ を上回っている (丨 >丨 〇リ 1:) と判定 された場合には、 保持完了条件は成立しているため、 3 1 4を介して 3 1 5 に進む。
[01 10] 図 1 2は、 パーキングブレーキ制御装置 2 4により図 4、 図 1 0、 図 1 1 に示す処理を行ったときのタイムチヤート (アプライ時のモータ電流丨 と液 圧 の時間変化) の一例を示している。 時点 1 1で、 モータ電流丨がそのと
〇 2020/175179 39 卩(:171? 2020 /005742
きの液圧 に応じたアプライー時停止電流閾値丨 3リ 3 ㊀を上回ることに より、 電動モータ 7八への電力供給が一時的に停止する。 第 2の実施形態で は、 パーキングブレーキ制御装置 2 4は、 アプライー時停止時間が経過した 時点 2で、 図 1 1の 3 2 1 - 2および 3 2 1 - 3の処理により、 「電動モ —夕 7八を停止したときの液圧 1 とアプライー時停止時間が経過したとき の液圧
 (= ? 2 - 1) 」 に基づいて、 保持完了条件を決定す る。
[01 1 1 ] 具体的には、 パーキングブレーキ制御装置 2 4は、 変化量
 が液圧変化
 3 Xより小さいときは、 アプライー時停止時間経過後に通電を再 開してモータ電流丨がアプライ完了電流閾値丨 〇リ Iを超えることを保持完 了条件として決定する。 パーキングブレーキ制御装置 2 4は、 アプライー時 停止時間が経過した時点 2で、 電動モータ 7八に対する通電を再開する。 パーキングブレーキ制御装置 2 4は、 モータ電流丨が電流閾値丨 〇
 1を上 回ると、 電動モータ 7八に対する通電 (再通電) を停止し、 アプライ処理を 終了する。 なお、 液圧 の変化量
 が液圧変化閾値八 3 Xより大きい ときは、 通電を再開しないことが保持完了条件となるため、 アプライー時停 止時間が経過した時点 2でアプライ処理が終了する。 これにより、 電動モ —夕 7八の一時停止中 (より具体的には、 一時停止前後) の液圧の変化量△ (= 2 - 1) に基づいて、 通電の再開の要否を決定し、 必要に応じて再 通電することにより推力の過不足を抑制できる。
[01 12] 第 2の実施形態は、 上述の如き図 4、 図 1 0、 図 1 1の処理に基づいて電 力供給の一時的な停止を含むアプライ処理を行うもので、 その基本的作用に ついては、 第 1の実施形態によるものと格別差異はない。 即ち、 第 2の実施 形態も、 第 1の実施形態と同様に、 アプライ完了時の推力の過不足を抑制で きる。
[01 13] なお、 各実施形態では、 パーキングブレーキ制御装置 2 4により、 〇八 (車両データバス 2 0) 経由で液圧
 を受信し、 こ の液圧 を用いてアプライ制御処理を行う構成とした場合を例に挙げて説明
〇 2020/175179 40 卩(:171? 2020 /005742
した。 しかし、 これに限らず、 例えば、 巳 3〇制御装置 1 7により電動パー キングブレーキを制御する (アプライ制御処理を行う) 場合等、 〇八!\1を経 由せずに巳 3(3 1 6の認識マスタ液圧を受信できる場合には、 その液圧値に 基づいて制御 (アプライ制御) をしてもよい。
[01 14] 各実施形態では、 液圧 として

げて説明した。 しかし、 これに限らず、 例えば、 液圧 として /〇液圧 等、
 以外の液圧を用いてもよい。 各実施形態では 、 車両状態として液圧 を用いる場合を例に挙げて説明した。 しかし、 これ に限らず、 車両状態として、 例えば、 ブレーキペダルの操作量、 倍力装置の 入力部材 (入カロッ ド) の変位量、 電動倍力装置の電動モータの回転量、 マ スタシリンダのピストンの変位量等、 液圧以外の車両状態 (車両状態量) を 用いてもよい。
[01 15] 各実施形態では、 通電一時停止時 (時点 1 1) から再開時 (時点 1 2) で の液圧差により変化量
 を算出する (かつ、 変化量△ に基づいて保持完 了条件を決定する) 構成とした場合を例に挙げて説明した。 しかし、 これに 限らず、 例えば、 通電一時停止前または通電停止後の液圧値を参照してもよ い (通電一時停止前または通電停止後の液圧値に基づいて、 保持完了条件を 決定してもよい) 。 これにより、 液圧変化を液圧情報の遅延時間が大きい場 合にアプライー時停止時間が過剰に長くなることを回避できる。 また、 通電 一時停止中の判定区間の最大液圧と最小液圧との差を変化量△ としてもよ い。 これにより、 液圧情報が真値より大きくなることによる推力不足への口 バスト性を向上できる。
[01 16] 第 2の実施形態では、 アプライ完了電流閾値 I 〇リ Iは、 液圧 によらず —定 (例えば、 液圧 が 0 1\/1 3のときに電動モータ 7八によって必要な推 力を付与することができる電流閾値 | 乂) として設定した場合を例に挙げて 説明した。 しかし、 これに限らず、 例えば、 アプライ完了電流閾値丨
 を、 図 7に示すアプライー時停止電流閾値 I
 のように、 液圧が高 いほど低くなるように設定してもよい。 これにより、 遅延による液圧誤差発
〇 2020/175179 41 卩(:171? 2020 /005742
生時でも推力抑制効果を得ることができる。
[01 17] 各実施形態では、 アプライ中に電力供給を一時的に停止しているときに保 持完了条件 (アプライ完了条件) を決定し、 この保持完了条件が成立したと きに制動力の保持を完了 (アプライを完了) させる構成とした場合を例に挙 げて説明した。 この場合に、 電力供給の一時的な停止は、 アプライ途中の一 時的な停止、 即ち、 アプライを開始してからアプライが完了するまでの間の 電力供給の一時的な停止に対応する。 これに対して、 このような電力供給の 一時的な停止を含むアプライが完了した後に、 必要に応じて、 再アプライ ( 再保持、 リクランプ) を行ってもよい。 例えば、 アプライ完了後の熱収縮に 伴う制動力の低下等を考慮して、 アプライ完了から所定時間経過後 (例えば 、 制動部材、 被制動部材の温度が低下する数分後) に、 再アプライ (再保持 、 リクランプ) を行ってもよい。 アプライ完了から再アプライを行うまでの 時間 (再アプライ開始時間) は、 アプライー時停止時間には相当しない。
[01 18] 各実施形態では、 後輪側ディスクブレーキ 6を電動パーキングブレーキ機 能付の液圧式ディスクプレーキとすると共に、 前輪側ディスクプレーキ 5を 電動パーキングブレーキ機能が付いていない液圧式ディスクブレーキとした 場合を例に挙げて説明した。 しかし、 これに限らず、 例えば、 後輪側ディス クプレーキ 6を電動パーキングブレーキ機能が付いていない液圧式ディスク ブレーキとすると共に、 前輪側ディスクブレーキ 5を電動パーキングブレー キ機能付の液圧式ディスクブレーキとしてもよい。 さらに、 前輪側ディスク ブレーキ 5と後輪側ディスクプレーキ 6との両方を、 電動パーキングブレー キ機能付の液圧式ディスクブレーキとしてもよい。 要するに、 車両の車輪の うち少なくとも左右一対の車輪のブレーキを電動パーキングブレーキにより 構成することができる。
[01 19] 各実施形態では、 液圧制動装置として液圧式のディスクブレーキ、 即ち、 後輪側ディスクブレーキ 6を例に挙げて説明した。 しかし、 これに限らず、 液圧制動装置は、 例えば、 液圧式のドラムブレーキ等、 各種の液圧制動装置 を用いてもよい。 各実施形態では、 電動ブレーキ装置として、 電動モータ 7
〇 2020/175179 42 卩(:171? 2020 /005742
八と回転直動機構 8とを備える構成とした場合を例に挙げて説明した。 しか し、 これに限らず、 電動機とラチェッ ト機構とを備える構成等、 各種の電動 ブレーキ装置 (電動ブレーキ機構、 電動パーキング機構) を用いてもよい。 即ち、 電動パーキングブレーキ機能付の液圧式ディスクブレーキ、 電動パー キングブレーキ機能付の液圧式ドラムブレーキ、 ディスクブレーキにドラム 式の電動パーキングブレーキを設けたドラムインディスクブレーキ、 電動モ —夕でケーブルを引っ張ることによりパーキングブレーキの保持を行う構成 等、 液圧制動装置と電動ブレーキ装置とにより構成される各種の電動パーキ ングブレーキ装置を採用することができる。 さらに、 各実施形態は例示であ り、 異なる実施形態で示した構成の部分的な置換または組み合わせが可能で あることは言うまでもない。
[0120] 以上説明した実施形態に基づくブレーキシステム、 ブレーキ制御装置、 ブ レーキ制御方法およびブレーキ制御プログラムとして、 例えば下記に述べる 態様のものが考えられる。
[0121 ] 第 1の態様としては、 車両に搭載されるブレーキシステムであって、 液圧 によってピストンを推進して制動部材を被制動部材に押圧する液圧制動装置 と、 電動機から伝達される推力によって前記ピストンを推進して前記制動部 材を前記被制動部材に押圧し、 制動力を保持する電動ブレーキ装置と、 制動 力を保持する場合に、 前記ビストンに推力が発生する区間において前記電動 機への電力供給を一時的に停止させたあとに前記電動機への電力供給を再開 し、 制動力の保持を完了させる保持完了条件が成立したときに制動力の保持 を完了させる制御装置と、 を備え、 前記制御装置は、 前記電力供給が一時的 に停止されているときに、 前記車両の車両状態の変化に基づき、 前記保持完 了条件を決定する。
[0122] この第 1の態様によれば、 電動機への電力供給を一時停止しているときに 、 制動力の保持を完了させる保持完了条件を、 車両状態の変化に基づいて決 定する。 これにより、 車両状態の変化に対応した保持完了条件で、 制動力の 保持を完了させることができる。 この場合に、 電力供給を一時停止すること
〇 2020/175179 43 卩(:171? 2020 /005742
により、 車両状態の情報 (例えば、 液圧情報) の遅延による影響 (誤差) を 抑制して、 そのときの車両状態 (の変化) に応じた適切な制動力で保持を完 了させることができる。 この結果、 電動機の駆動に基づいて制動力を保持す るときの車両状態の変化に伴う推力の過不足 (過剰、 不足) を抑制すること ができる。
[0123] 第 2の態様としては、 第 1の態様において、 前記制御装置は、 制動力の保 持を開始するときの前記ピストンに付与されている液圧に応じて前記電動機 への電力供給を一時的に停止させるための電流閾値を変更する。 この第 2の 態様によれば、 電動機への電力供給の一時停止を、 液圧に応じた適切な電流 閾値で行うことができる。 即ち、 推力が過剰になる前に電力供給を一時停止 できる。 そして、 一時停止しているときの車両状態の変化に基づき電力供給 の再開が必要なときは、 電力供給を再開することで、 推力が不足することを 抑制できる。
[0124] 第 3の態様としては、 第 1の態様において、 前記車両状態は、 前記ピスト ンに付与されている液圧であり、 前記制御装置は、 前記ピストンに付与され ている液圧の変化により前記保持完了条件を決定する。 この第 3の態様によ れば、 液圧の変化に対応した保持完了条件で、 制動力の保持を完了させるこ とができる。
[0125] 第 4の態様としては、 第 3の態様において、 前記制御装置は、 電力供給が 一時的に停止されている間の液圧の変化量が大きいほど電力供給の再開後の 電力供給時間が長くなるように前記保持完了条件を決定する。 この第 4の態 様によれば、 例えば、 液圧が減圧側に大きく変化するほど (減圧量が大きい ほど) 電力供給の再開後の電力供給時間を長くすることで、 推力の不足を抑 制できる。 この場合、 推力が過剰になることを抑制すべく、 推力が低い状態 で電力供給を一時停止しても、 制動力の保持を完了したときの推力の不足を 抑制できる。
[0126] 第 5の態様としては、 車両に搭載されるブレーキ制御装置であって、 液圧 または電動機から伝達される推力によってピストンを推進して制動部材を被
〇 2020/175179 44 卩(:171? 2020 /005742
制動部材に押圧するブレーキ機構における前記電動機を制御する制御部を有 し、 前記制御部は、 前記ブレーキ機構の制動力を保持する制御指令に応じて 前記電動機を駆動し、 前記ピストンに推力が発生している電流上昇の際に、 前記電動機への電力供給を一時的に停止させたあとに前記電動機への電力供 給を再開し、 制動力の保持を完了させる保持完了条件が成立したときに制動 力の保持を完了させ、 前記電動機への電力供給を一時的に停止しているとき に、 前記車両の車両状態の変化に基づき、 前記保持完了条件を決定する。 こ の第 5の態様によれば、 電動機の駆動に基づいて制動力を保持するときの車 両状態の変化に伴う推力の過不足 (過剰、 不足) を抑制することができる。
[0127] 第 6の態様としては、 第 5の態様において、 前記制御部は、 制動力の保持 を開始するときに、 前記ブレーキ機構へ付加される液圧を取得し、 当該取得 した液圧に応じて前記電動機への電力供給を一時的に停止させるための電流 閾値を設定する。 この第 6の態様によれば、 電動機への電力供給の一時停止 を、 液圧に応じた適切な電流閾値で行うことができる。
[0128] 第 7の態様としては、 第 5の態様において、 前記制御部は、 前記車両状態 として、 前記ピストンに付与されている液圧を取得し、 当該液圧の変化に基 づいて前記保持完了条件を設定する。 この第 7の態様によれば、 液圧の変化 に対応した保持完了条件で、 制動力の保持を完了させることができる。
[0129] 第 8の態様としては、 第 7の態様において、 前記制御部は、 電力供給が一 時的に停止されている間の液圧の変化量が大きいほど電力供給の再開後の電 力供給時間が長くなるように、 前記保持完了条件を設定する。 この第 8の態 様によれば、 制動力の保持を完了したときの推力の不足を抑制できる。
[0130] 第 9の態様としては、 液圧または電動機から伝達される推力によってビス トンを推進して制動部材を被制動部材に押圧するブレーキ機構における前記 電動機を制御するブレーキ制御方法であって、 前記ブレーキ機構の制動力を 保持する制御指令に応じて前記電動機への電流供給を開始するステップと、 前記ピストンに推力が発生している電流上昇の際に、 前記電動機への電力供 給を一時的に停止させるステップと、 前記電動機への電力供給を一時的に停
〇 2020/175179 45 卩(:171? 2020 /005742
止しているときに、 前記ブレーキ機構が搭載された車両の車両状態の変化に 基づき、 制動力の保持を完了させる保持完了条件を設定するステップと、 前 記電動機への電力供給を一時的に停止させた後、 前記電動機への電力供給を 再開するステップと、 前記保持完了条件が成立したときに制動力の保持を完 了させるステップと、 を含む。 この第 9の態様によれば、 電動機の駆動に基 づいて制動力を保持するときの車両状態の変化に伴う推力の過不足 (過剰、 不足) を抑制することができる。
[0131 ] この第 1 0の態様としては、 第 9の態様において、 ブレーキ制御方法は、 前記電動機への電流供給を開始するときに、 前記ブレーキ機構へ付加される 液圧を取得し、 当該取得した液圧に応じて前記電動機への電力供給を一時的 に停止させるための電流閾値を設定するステップをさらに含む。 この第 1 0 の態様によれば、 電動機への電力供給の一時停止を、 液圧に応じた適切な電 流閾値で行うことができる。
[0132] 第 1 1の態様としては、 第 9の態様において、 前記保持完了条件を設定す るステップにおいて、 前記車両状態として、 前記ピストンに付与されている 液圧が取得され、 当該液圧の変化に基づいて前記保持完了条件が設定される 。 この第 1 1の態様によれば、 液圧の変化に対応した保持完了条件で、 制動 力の保持を完了させることができる。
[0133] 第 1 2の態様としては、 第 1 1の態様において、 前記保持完了条件を設定 するステップにおいて、 前記電力供給が一時的に停止されている間の液圧の 変化量が大きいほど電力供給の再開後の電力供給時間が長くなるように、 前 記保持完了条件が設定される。 この第 1 2の態様によれば、 制動力の保持を 完了したときの推力の不足を抑制できる。
[0134] 第 1 3の態様としては、 液圧または電動機から伝達される推力によってピ ストンを推進して制動部材を被制動部材に押圧するブレーキ機構における前 記電動機を制御するブレーキ制御装置に実行させるブレーキ制御プログラム であって、 前記ブレーキ機構の制動力を保持する制御指令に応じて前記電動 機への電流供給を開始するステップと、 前記ビストンに推力が発生している
〇 2020/175179 46 卩(:171? 2020 /005742
電流上昇の際に、 前記電動機への電力供給を一時的に停止させるステップと 、 前記電動機への電力供給を一時的に停止しているときに、 前記ブレーキ機 構が搭載された車両の車両状態の変化に基づき、 制動力の保持を完了させる 保持完了条件を設定するステップと、 前記電動機への電力供給を一時的に停 止させた後、 前記電動機への電力供給を再開するステップと、 前記保持完了 条件が成立したときに制動力の保持を完了させるステップと、 を実行する。 この第 1 3の態様によれば、 電動機の駆動に基づいて制動力を保持するとき の車両状態の変化に伴う推力の過不足 (過剰、 不足) を抑制することができ る。
[0135] 第 1 4の態様によれば、 第 1 3の態様において、 ブレーキ制御プログラム は、 前記電動機への電流供給を開始するときに、 前記ブレーキ機構へ付加さ れる液圧を取得し、 当該取得した液圧に応じて前記電動機への電力供給を一 時的に停止させるための電流閾値を設定するステップをさらに実行する。 こ の第 1 4の態様によれば、 電動機への電力供給の一時停止を、 液圧に応じた 適切な電流閾値で行うことができる。
[0136] 第 1 5の態様としては、 第 1 3の態様において、 前記保持完了条件を設定 するステップにおいて、 前記車両状態として、 前記ピストンに付与されてい る液圧が取得され、 当該液圧の変化に基づいて前記保持完了条件が設定され る。 この第 1 5の態様によれば、 液圧の変化に対応した保持完了条件で、 制 動力の保持を完了させることができる。
[0137] 第 1 6の態様としては、 第 1 5の態様において、 前記保持完了条件を設定 するステップにおいて、 前記電力供給が一時的に停止されている間の液圧の 変化量が大きいほど電力供給の再開後の電力供給時間が長くなるように、 前 記保持完了条件が設定される。 この第 1 6の態様によれば、 制動力の保持を 完了したときの推力の不足を抑制できる。
[0138] なお、 本発明は上記した実施形態に限定されるものではなく、 様々な変形 例が含まれる。 例えば、 上記した実施形態は本発明を分かりやすく説明する ために詳細に説明したものであり、 必ずしも説明した全ての構成を備えるも
〇 2020/175179 47 卩(:171? 2020 /005742
のに限定されるものではない。 また、 ある実施形態の構成の一部を他の実施 形態の構成に置き換えることが可能であり、 また、 ある実施形態の構成に他 の実施形態の構成を加えることも可能である。 また、 各実施形態の構成の一 部について、 他の構成の追加 ·削除 ·置換をすることが可能である。
[0139] 本願は、 201 9年2月 26日付出願の日本国特許出願第 201 9— 03
2701号に基づく優先権を主張する。 201 9年 2月 26日付出願の日本 国特許出願第 201 9-032701号の明細書、 特許請求の範囲、 図面、 および要約書を含む全開示内容は、 参照により本願に全体として組み込まれ る。
符号の説明
[0140] 4 ディスクロータ (被制動部材) 6 後輪側ディスクブレーキ (ブレ
—キ機構) 6巳 キヤリバ (液圧制動装置) 60 ブレーキパッ ド (制 動部材) 60 ピストン (液圧制動装置) 7八 電動モータ (電動ブレ
—キ装置、 電動機) 8 回転直動機構 (電動ブレーキ装置) 24 パー キングブレーキ制御装置 (制御装置、 ブレーキ制御装置)
Claims
[請求項 1 ] 車両に搭載されるブレーキシステムであって、
液圧によってピストンを推進して制動部材を被制動部材に押圧する 液圧制動装置と、
電動機から伝達される推力によって前記ピストンを推進して前記制 動部材を前記被制動部材に押圧し、 制動力を保持する電動ブレーキ装 置と、
制動力を保持する場合に、 前記ピストンに推力が発生する区間にお いて前記電動機への電力供給を一時的に停止させたあとに前記電動機 への電力供給を再開し、 制動力の保持を完了させる保持完了条件が成 立したときに制動力の保持を完了させる制御装置と、 を備え、 前記制御装置は、 前記電力供給が一時的に停止されているときに、 前記車両の車両状態の変化に基づき、 前記保持完了条件を決定する、 ブレーキシステム。
[請求項 2] 請求項 1記載のブレーキシステムであって、
前記制御装置は、 制動力の保持を開始するときの前記ピストンに付 与されている液圧に応じて前記電動機への電力供給を一時的に停止さ せるための電流閾値を変更する、 ブレーキシステム。
[請求項 3] 請求項 1記載のブレーキシステムであって、
前記車両状態は、 前記ピストンに付与されている液圧であり、 前記制御装置は、 前記ピストンに付与されている液圧の変化により 前記保持完了条件を決定する、 ブレーキシステム。
[請求項 4] 請求項 3記載のブレーキシステムであって、
前記制御装置は、 電力供給が一時的に停止されている間の液圧の変 化量が大きいほど電力供給の再開後の電力供給時間が長くなるように 前記保持完了条件を決定する、 ブレーキシステム。
[請求項 5] 車両に搭載されるブレーキ制御装置であって、
液圧または電動機から伝達される推力によってピストンを推進して
〇 2020/175179 49 卩(:171? 2020 /005742
芾 I」動部材を被制動部材に押圧するブレーキ機構における前記電動機を 制御する制御部を有し、
前記制御部は、 前記ブレーキ機構の制動力を保持する制御指令に応 じて前記電動機を駆動し、 前記ピストンに推力が発生している電流上 昇の際に、 前記電動機への電力供給を一時的に停止させたあとに前記 電動機への電力供給を再開し、 制動力の保持を完了させる保持完了条 件が成立したときに制動力の保持を完了させ、
前記電動機への電力供給を一時的に停止しているときに、 前記車両 の車両状態の変化に基づき、 前記保持完了条件を決定する、 ブレーキ 制御装置。
[請求項 6] 請求項 5記載のブレーキ制御装置であって、
前記制御部は、 制動力の保持を開始するときに、 前記ブレーキ機構 へ付加される液圧を取得し、 当該取得した液圧に応じて前記電動機へ の電力供給を一時的に停止させるための電流閾値を設定する、 ブレー キ制御装置。
[請求項· 7] 請求項 5記載のブレーキ制御装置であって、
前記制御部は、 前記車両状態として、 前記ピストンに付与されてい る液圧を取得し、 当該液圧の変化に基づいて前記保持完了条件を設定 する、 ブレーキ制御装置。
[請求項 8] 請求項 7記載のブレーキ制御装置であって、
前記制御部は、 電力供給が一時的に停止されている間の液圧の変化 量が大きいほど電力供給の再開後の電力供給時間が長くなるように、 前記保持完了条件を設定する、 ブレーキ制御装置。
[請求項 9] 液圧または電動機から伝達される推力によってピストンを推進して 芾 I」動部材を被制動部材に押圧するブレーキ機構における前記電動機を 制御するブレーキ制御方法であって、
前記ブレーキ機構の制動力を保持する制御指令に応じて前記電動機 への電流供給を開始するステップと、
〇 2020/175179 50 卩(:171? 2020 /005742
前記ピストンに推力が発生している電流上昇の際に、 前記電動機へ の電力供給を一時的に停止させるステップと、
前記電動機への電力供給を一時的に停止しているときに、 前記ブレ —キ機構が搭載された車両の車両状態の変化に基づき、 制動力の保持 を完了させる保持完了条件を設定するステップと、 前記電動機への電力供給を一時的に停止させた後、 前記電動機への 電力供給を再開するステップと、
前記保持完了条件が成立したときに制動力の保持を完了させるステ ップと、 を含む、 ブレーキ制御方法。
[請求項 10] 請求項 9記載のブレーキ制御方法であって、 前記ブレーキ制御方法 は、
前記電動機への電流供給を開始するときに、 前記ブレーキ機構へ付 加される液圧を取得し、 当該取得した液圧に応じて前記電動機への電 力供給を一時的に停止させるための電流閾値を設定するステップをさ らに含む、 ブレーキ制御方法。
[請求項 1 1 ] 請求項 9記載のブレーキ制御方法であって、
前記保持完了条件を設定するステップにおいて、 前記車両状態とし て、 前記ピストンに付与されている液圧が取得され、 当該液圧の変化 に基づいて前記保持完了条件が設定される、 ブレーキ制御方法。
[請求項 12] 請求項 1 1記載のブレーキ制御方法であって、
前記保持完了条件を設定するステップにおいて、 前記電力供給が一 時的に停止されている間の液圧の変化量が大きいほど電力供給の再開 後の電力供給時間が長くなるように、 前記保持完了条件が設定される 、 ブレーキ制御方法。
[請求項 13] 液圧または電動機から伝達される推力によってピストンを推進して 制動部材を被制動部材に押圧するブレーキ機構における前記電動機を 制御するブレーキ制御装置に実行させるブレーキ制御プログラムであ つて、
〇 2020/175179 51 卩(:171? 2020 /005742
前記ブレーキ機構の制動力を保持する制御指令に応じて前記電動機 への電流供給を開始するステップと、
前記ピストンに推力が発生している電流上昇の際に、 前記電動機へ の電力供給を一時的に停止させるステップと、
前記電動機への電力供給を一時的に停止しているときに、 前記ブレ —キ機構が搭載された車両の車両状態の変化に基づき、 制動力の保持 を完了させる保持完了条件を設定するステップと、 前記電動機への電力供給を一時的に停止させた後、 前記電動機への 電力供給を再開するステップと、
前記保持完了条件が成立したときに制動力の保持を完了させるステ ップと、 を実行するブレーキ制御プログラム。
[請求項 14] 請求項 1 3記載のブレーキ制御プログラムであって、 前記ブレーキ 制御プログラムは、
前記電動機への電流供給を開始するときに、 前記ブレーキ機構へ付 加される液圧を取得し、 当該取得した液圧に応じて前記電動機への電 力供給を一時的に停止させるための電流閾値を設定するステップをさ らに実行する、 ブレーキ制御プログラム。
[請求項 15] 請求項 1 3記載のブレーキ制御プログラムであって、
前記保持完了条件を設定するステップにおいて、 前記車両状態とし て、 前記ピストンに付与されている液圧が取得され、 当該液圧の変化 に基づいて前記保持完了条件が設定される、 ブレーキ制御プログラム
[請求項 16] 請求項 1 5記載のブレーキ制御プログラムであって、
前記保持完了条件を設定するステップにおいて、 前記電力供給が一 時的に停止されている間の液圧の変化量が大きいほど電力供給の再開 後の電力供給時間が長くなるように、 前記保持完了条件が設定される 、 ブレーキ制御プログラム。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019-032701 | 2019-02-26 | ||
| JP2019032701A JP2022065211A (ja) | 2019-02-26 | 2019-02-26 | ブレーキシステム、ブレーキ制御装置、ブレーキ制御方法およびブレーキ制御プログラム |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020175179A1 true WO2020175179A1 (ja) | 2020-09-03 |
Family
ID=72238368
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2020/005742 Ceased WO2020175179A1 (ja) | 2019-02-26 | 2020-02-14 | ブレーキシステム、ブレーキ制御装置、ブレーキ制御方法およびブレーキ制御プログラム |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JP2022065211A (ja) |
| WO (1) | WO2020175179A1 (ja) |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2014046824A (ja) * | 2012-08-31 | 2014-03-17 | Hitachi Automotive Systems Ltd | ブレーキ装置 |
| JP2016124408A (ja) * | 2014-12-27 | 2016-07-11 | 日立オートモティブシステムズ株式会社 | 電動ブレーキシステム |
-
2019
- 2019-02-26 JP JP2019032701A patent/JP2022065211A/ja active Pending
-
2020
- 2020-02-14 WO PCT/JP2020/005742 patent/WO2020175179A1/ja not_active Ceased
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2014046824A (ja) * | 2012-08-31 | 2014-03-17 | Hitachi Automotive Systems Ltd | ブレーキ装置 |
| JP2016124408A (ja) * | 2014-12-27 | 2016-07-11 | 日立オートモティブシステムズ株式会社 | 電動ブレーキシステム |
Also Published As
| Publication number | Publication date |
|---|---|
| JP2022065211A (ja) | 2022-04-27 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7153743B2 (ja) | 電動ブレーキ装置 | |
| CN103029698B (zh) | 制动控制装置 | |
| US8382642B2 (en) | Vehicle control apparatus | |
| JP7058327B2 (ja) | 電動ブレーキ装置、電動ブレーキ制御装置およびブレーキ制御装置 | |
| JP7049841B2 (ja) | 電動ブレーキ装置 | |
| JP7584644B2 (ja) | ブレーキ装置の制御装置、ブレーキ装置の制御方法およびブレーキ装置 | |
| WO2012043641A1 (ja) | 車両の制御装置及び制御方法 | |
| US12134375B2 (en) | Electric brake device and electric brake control device | |
| JP2009190648A (ja) | ブレーキ制御装置 | |
| JP2018184093A (ja) | 電動ブレーキ装置 | |
| JP6807720B2 (ja) | 電動ブレーキ装置 | |
| WO2014021311A1 (ja) | 電動駐車ブレーキ制御装置 | |
| JP6839892B2 (ja) | ブレーキシステム | |
| JP2018114940A (ja) | ブレーキシステム | |
| JP7352403B2 (ja) | 電動ブレーキ装置およびブレーキ制御装置 | |
| JP7018362B2 (ja) | 電動ブレーキ装置 | |
| JP2019130938A (ja) | 電動ブレーキ装置および電動ブレーキ制御装置 | |
| JP5630130B2 (ja) | 電動車両のブレーキ制御装置 | |
| CN118742469A (zh) | 电动制动装置、电动制动控制方法以及控制装置 | |
| JP2019157921A (ja) | 電動ブレーキ装置および電動ブレーキ制御装置 | |
| JP4499691B2 (ja) | 制動制御装置 | |
| JP2007276683A (ja) | 車両用ブレーキ制御装置 | |
| CN114379523B (zh) | 车辆的制动控制装置 | |
| JP2022065211A (ja) | ブレーキシステム、ブレーキ制御装置、ブレーキ制御方法およびブレーキ制御プログラム | |
| JP7290007B2 (ja) | エンジン制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20763760 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 20763760 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: JP |