EP4169867B1 - Lift arm and vehicle lift - Google Patents
Lift arm and vehicle lift Download PDFInfo
- Publication number
- EP4169867B1 EP4169867B1 EP22198153.3A EP22198153A EP4169867B1 EP 4169867 B1 EP4169867 B1 EP 4169867B1 EP 22198153 A EP22198153 A EP 22198153A EP 4169867 B1 EP4169867 B1 EP 4169867B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- base body
- insert
- distal body
- lift arm
- distal
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66F—HOISTING, LIFTING, HAULING OR PUSHING, NOT OTHERWISE PROVIDED FOR, e.g. DEVICES WHICH APPLY A LIFTING OR PUSHING FORCE DIRECTLY TO THE SURFACE OF A LOAD
- B66F7/00—Lifting frames, e.g. for lifting vehicles; Platform lifts
- B66F7/28—Constructional details, e.g. end stops, pivoting supporting members, sliding runners adjustable to load dimensions
Definitions
- the present invention relates to a lift arm as well as a vehicle lift and a vehicle lift process using said arm.
- the present invention may be used in the automotive field for servicing vehicles, e.g., cars, trucks or agricultural vehicles.
- Column lifts comprise one or more vertical support columns each of which carries a carriage provided with a nair of adjustable and/or extendable arms, as shown in the US Patent No. US 4,825,977 : the ends of the arms comprise height-adjustable pads configured to receive the vehicle to be lifted.
- the movement of each carriage is performed by electromechanical systems, e.g., an electric motor operating on a mother-screw type system, or by hydraulic cylinders.
- U.S. Patent Application No. US 2020/0079627 A1 describes a two-column lift comprising, for each column, two telescopic lift arms hinged to a carriage vertically movable along the respective column. Each arm extends along a rectilinear direction and terminally carries an adapter configured to contact a vehicle: the adapter is hinged to the arm. Rotation between the adapter and the arm may be locked by a further pin insertable through appropriate holes defined on respective plates of the adapter and the telescopic arm.
- US 2020/0079627 A1 discloses the preamble of claim 1.
- US patent application No. US 2019/0276287 A1 also describes a two-column lift comprising, for each column, a first and a second arm hinged to a carriage vertically movable along the respective column.
- the first arm may be telescopic and extends along a rectilinear direction;
- the second arm includes a base body, directly hinged to the carriage, and a distal body hinged to the base body: the distal body includes a height adjustable support configured to contact a vehicle.
- the base body and the distal body are equal in length and hinged at an intermediate joint. Relative rotation between the base body and the distal body of the second arm may be locked by a lever carried by the base body engaging a toothed disc on the second arm.
- lifts of the state of the art are not devoid of limitations and drawbacks.
- Such lifts have articulated lift arms having a complex, bulky, and difficult to implement rotation lock system; such lock systems are not capable of ensuring rapid and safe locking of the rotation of the articulated arm, a condition which negatively affects on safety and productivity.
- the known lifts are used for lifting vehicles, the Applicant observed that such lifts are not devoid of limitations and drawbacks, therefore being subject to improvement from various points.
- the object of the present invention is to overcome at least one of the drawbacks and/or limitations of the previous solutions.
- An object of the present invention is to provide a lift arm and a respective lift having a simple and compact structure, which has low production costs and which at the same time is structurally robust, and able to safely and quickly lift vehicles. Furthermore, an object of the present invention is to provide a lift arm and a respective vehicle lift capable of guaranteeing the effective and quick lifting of a wide range of transport means. Furthermore, another object of the present invention is to provide a lift capable of operating in a safe and reliable manner, in particular capable of lifting vehicles without damaging said vehicle and/or components of the lift itself.
- horizontal or vertical used in relation to components of the lift, refer to a condition of use of the lift during which the lift executes, or is usable, for executing raising/lowering of a vehicle.
- Reference number 30 indicates a lift arm for a vehicle lift.
- the lift arm 30 may be used in the automotive industry for servicing vehicles, e.g., cars, trucks, agricultural vehicles.
- the lift arm 30 is usable in association with at least one column of a vehicle lift to allow lifting of the vehicle with respect to the ground.
- the lift arm 30 includes a base body 31 extending between a first and a second end portion 31a, 31b along an, optionally rectilinear, extension path D.
- the base body 31 has an elongated conformation; the base body 31 has a predetermined length defined by the maximum distance between the first and the second end portions 31a, 31b: said length of base body 31 may be, for example, equal to or greater than 500 mm, optionally comprised between 500 mm and 1200 mm.
- the length of base body 31 may be fixed or adjustable.
- the lift arm 30 is extendable: the distance between the first and second end portions 31a, 31b is adjustable, for example by means of an actuator 60 ( Figure 8 ).
- the actuator 60 may comprise at least one of: a hydraulic cylinder, a pneumatic cylinder, an electric motor.
- the base body 31 may have a first section and a second section, which are movable with respect to each other along the extension path D of the base body 31 to adjust a length of the base body 31.
- the first section may extend from the first end portion 31a to a centerline portion of the base body 31 while the second section may extend from the second end portion 31b to the centerline portion of the base body 31.
- the actuator 60 may be engaged, on one side, to the first section and, on the other side, to the second section: activation of the actuator 60 allows to approach or move away the first and second end portions 31a, 31b.
- the base body 31 may be at least partly hollow and internally define a housing compartment A suitable for at least partly receiving said actuator 60: in such a configuration, the actuator 60 would be at least partly hidden within the base body 31.
- both the first section and the second section of the base body 31 may be hollow and internally define a respective housing compartment ( Figure 8 ); the second section of the base body 31 may be placed at least partially within the first section and be slidingly movable at least partially within said first section of the same base body 31.
- the actuator 60 is arranged within the housing compartments defined by the first and second sections of the base body 31: the housing compartments of the first and second sections of the base body 31 communicate with each other and cooperate to define a single housing compartment A of the base body 31 ( Figure 8 ).
- the base body 31 may present a box shape, for example, the base body may have a cross section, in plane orthogonal to the extension path D of the base body 31, having substantially square or rectangular shape.
- Such cross section may be constant along the entire extension of the base body or it may get smaller moving towards the second end portion.
- the first section of the base body may have cross section greater than the cross section of the second section of the same base body 31; in this way, the first section may internally receive the second section of the base body and guide movement of the second section of the same base body 31.
- the possibility of fixed, non-extendable, base body 31 is not excluded.
- the base body 31 may comprise at least one attachment portion 33 configured for engagement of the lift arm 30 to at least one carriage 3 of a lift 1 (see Figures 1 and 2 ).
- the attachment portion 33 may comprise at least one plate suitable for being hinged, for example by means of a cylindrical pin, to a carriage 3 of a lift, such that the lift arm may rotate with respect to the carriage about an axis Y, in particular orthogonal to the extension path of the base body 31.
- the base body 31 comprises an engagement portion coupling the base body 31 with a distal body 32 of the same lift arm 30.
- the engagement portion of the base body 31 comprises at least one plate 35 (see Figures 4 and 7 ) having at least one through hole for receiving a cylindrical pin 39 configured to engage the base body 31 and the distal body 32.
- the engagement portion of the base body 31 comprises two plates 35 spaced apart from each other, each of which has at least one through hole suitable to receive the cylindrical pin 39.
- the plate(s) 35 define the second end portion 31b of the base body 31 receiving and engaging the distal body 32.
- the distal body 32 extends between a first and a second end portions 32a, 32b, along a respective extension path T, optionally rectilinear ( Figures 6 and 8 ).
- the distal body 32 has an elongated conformation; the distal body 32 has a length defined by the maximum distance between the first and second end portions 32a, 32b: such length of the distal body may be equal to or greater than 100 mm, and may be optionally comprised between 100 mm and 500 mm.
- the length of the base body 31 is greater than the length of the distal body 32; for example, the ratio between the length of the base body 31 and the length of the distal body 32 may be greater than 3, and optionally between 4 and 8.
- the base body 31 and the distal body 32 may relatively rotate at least around an axis Z.
- the distal body 32 is hinged to the base body 31 at the second end portion 31b.
- the base body 31 and the distal body 32 are hinged at the second end portion 31b of the base body 31 and at the first end portion 32a of the distal body 32.
- the distal body 32 is thus a movable extension of the base body 31.
- the Z-axis of relative rotation between the base body 31 and the distal body 32 is orthogonal to the extension path D of the base body 31, in particular, the Z-axis may be orthogonal to both extension paths D and T respectively of base body 31 and distal body 32.
- the base body 31 is coupled to the distal body 32 by a flat hinge allowing only the relative rotation of the bodies 31, 32 about the single axis Z.
- the base body 31 and the distal body 32 are movable at least between:
- the engagement portion of the distal body 32 comprises at least one plate 34 at least partially overlapping plate 35 of the base body 31.
- plate 34 of the distal body 32 is placed between said two plates 35.
- Plate 34 of the distal body 32 comprises a respective through hole aligned with the at least one through hole of plate 35 of the base body 31.
- the base body 31 is engaged to the distal body 32 by cylindrical pin 39 ( Figure 4 ) which crosses the through-holes of the respective plates 34 and 35.
- Lift arm 30 may further comprise at least one support 5 carried by the distal body 32 and configured to directly contact the vehicle.
- the support 5 is arranged at the second end portion 32b of the distal body 32 and protrudes from the distal body along a direction which is transverse, optionally orthogonal, to the extension path T of the distal body (in particular orthogonally to the ideal plane defined by the extension paths D and T of the base body 31 and the distal body 32).
- Support 5 may move relative to the distal body 32 towards to and away from the ideal plane.
- support 5 may freely rotate, with respect to distal body 32 about an own axis W; axis W may be substantially parallel to axis Z of rotation of the base body 31 relative the distal body 32.
- Lift arm 30 further comprises a lock system 40 configured to block relative rotation between the base body 31 and the distal body 32.
- the base body 31 and the distal body 32 are movable with respect to each other such that the distal body 32 may be oriented to properly contact the vehicle without causing damage to vehicle parts, for example to a vehicle battery pack; after having properly orientated the distal body 32, the relative position between the distal body 32 and the base body 31 may be locked to provide the lift arm with a certain stability and to avoid undesired movements that could cause the vehicle roll over lift arm 30.
- the lock system 40 comprises at least one insert 41 movable at least between:
- Insert 41 is carried by at least one of said base body 31 and said distal body 32 and it is slidingly movable with respect to said bodies between the gripping position and the release position, and vice versa along at least a trajectory substantially parallel to at least one section of at least one of the extension path D of the base body 31 and the extension path T of the distal body 32.
- the insert 41 has a substantially parallelepiped, optionally rectangular parallelepiped, shape, and longitudinally extends between a head surface 40b facing the distal body 32, and a bottom surface 40a facing the first end portion 31a of the same base body 31 carrying the insert 41.
- the insert 41 (carried by the base body 31) has an engagement portion 46 which, in the gripping position, is configured to constrain an engagement portion 50 of the distal body 32: the engagement portion 46 of the insert 41 emerges from the head surface 40b in the direction of the distal body 32.
- the engagement portion 46 of the insert 41 may comprise at least one tooth 46a configured to cooperate with a toothed profile 51 of the engagement portion 50 of the distal body 32; in particular, the engagement portion 46 of the insert 41 may comprise a plurality of teeth 46a ( Figure 6 ) configured to cooperate with the toothed profile 51 of the engagement portion 50 of the distal body 32.
- the teeth 46a of the engagement portion 46 may be aligned along a direction which is transverse, optionally orthogonal, to the movement direction of the insert 41, namely being aligned according to an alignment direction, which is orthogonal to the extension path D of the base body 31 and parallel to the ideal plane.
- the head surface 40b may be flat: the plurality of teeth 46a may emerge from said flat head surface 40b.
- the plurality of teeth 46a of the insert 41 would be aligned along an arc profile such that said teeth 46a may essentially define a portion of a toothed wheel suitable to engage the toothed profile 51 of the distal body 32.
- the insert 41 may have a number of teeth 46a equal to or greater than 2, optionally between 3 and 5.
- the toothed profile 51 of the engagement portion 50 of the distal body 32 may comprise, in a non-limiting way, a plurality of teeth aligned along a respective arc shaped trajectory; the plurality of teeth of the engagement portion 50 of the distal body 32, in the gripping position of the insert 41, is configured to cooperate with the at least one tooth 46a of the engagement portion 46 of the insert 41 to block relative rotation between the base body 31 and the distal body 32.
- the arc-shaped trajectory of alignment of the teeth of toothed profile 51 lies in a plane substantially parallel to the ideal plane.
- the toothed profile 51 is defined at the first end portion 32a and is directed towards the base body 31; the toothed profile 51 emerges substantially from a curved end surface of distal body 32 and therefore directly faces tooth 46a of insert 41 (see, for example, the detail Figures 5A and 6 ).
- the use of a toothed profile 51 extending along a rectilinear trajectory, i.e., emerging towards the base body 31 from a flat end surface of the distal body 32 (condition not illustrated), is not excluded.
- the insert 41 may be placed at an external surface of the base body 31 or integrated within the base body 31.
- the insert 41 is placed, in a non-limiting way, within a seat 44 of the base body 31 ( Figures 5-6 ).
- the seat 44 is placed at the second end portion 31b and has a substantially "U" shape, with concavity directed towards the distal body 32: the seat 44 of the base body 31 is open.
- the seat 44 is at least partially counter-shaped to the insert 41 so that the insert is guided in its movement between the release position and the gripping position, and vice versa.
- insert 41 at least in the release position, is entirely housed in the seat 44 of the base body 31.
- the head surface 40b of the insert 41 is placed near a front free edge of said seat: the at least one tooth 46a (optionally the plurality of teeth 46a) of insert 41, in the gripping position, at least partially protrudes from seat 44 to contact the toothed profile 51 of the distal body.
- the lock system 40 may comprise a return element 42 configured to thrust on the insert 41 and force it to normally stay in the gripping position.
- the return element 42 is configured to normally keep insert 41 in the gripping position where insert 41 is constrained to the engagement portion 50 of the distal body 32 to thereby prevent relative rotation between the base body 31 and the distal body 32.
- the return element 42 on one side, contacts the base body 31 and, on the other side, contacts the insert 41 to keep the insert normally in the gripping position.
- return element 42 is placed entirely inside seat 44 between a bottom wall of the seat 44 and the bottom wall 40a of the insert: the return element pushes the bottom of insert 41 to force the engagement of tooth 46a with toothed profile 51 of the distal body 32.
- the return element 42 may be an elastic return element and may comprise at least one of: a torsion spring, a compression spring, a tension spring, an air spring, a leaf spring.
- the return element comprises, in a non-limiting way, a compression spring, on one side, resting on the bottom wall of the seat (wall directly facing the bottom surface 40a of the insert 41), and, on the opposite side, at least partially housed inside a guide seat on bottom surface 40a of the insert 41.
- a different return element 42 for example an actuator comprising at least one of: a magnetic or electromagnetic actuator, a hydraulic actuator, or a pneumatic actuator.
- the insert 41 may be moved from the gripping position to the release position by an operator manual action or by an actuator, for example comprising at least one of: a magnetic or electromagnetic actuator, a hydraulic actuator or a pneumatic actuator.
- Lift arm 30 may also comprise at least one maneuvering element 43 engaged to the insert 41 and emerging from at least one of the base body 31 and the distal body 32; the maneuvering element 43 is configured to be manually operated to move the insert 41 at least between the gripping position and the release position.
- the maneuvering element 43 includes a push portion 43b directly engaged to the insert 41 and a lever 43a allowing an operator to impose a movement to the insert 41 at least between the gripping position and the release position.
- the insert 41 may comprise at least one seat 41a ( Figure 7 ) within which the thrust portion 43b of the maneuvering element 43 is engaged.
- Seat 41a may have a cylindrical shape whereas the thrust portion 43b of the maneuvering element 43 may comprise a cylindrical pin at least partially counter-shaped to seat 41a.
- the thrust portion 43b is displaced thanks to manual intervention of the operator, from outside the base body 31, on lever 43a: displacement of the thrust portion 43b allows guiding the sliding insert from the gripping position to the release position to allow consequent disengagement of tooth 46a from toothed profile 51.
- Figure 5A shows the maneuvering element 43 which, in addition to being engaged in the insert, may further have a support end 43c allowing the maneuvering element to engage the base body 31.
- the base body 31 has a recess 47 delimited by at least one abutment wall; recess 47 is placed at the side of seat 44 of the same base body 31: recess 47 and seat 44 of base body 31 are in communication with each other and define a single pocket suitable to receive insert 41 and at least part of maneuvering element 43 (see, for example, Figure 5A ).
- the support end 43c of maneuvering element 43 opposed to the lever 43a and it is configured to be positioned within the recess, resting against the abutment wall to allow an operator, during (optionally manual) movement of the maneuvering element 43 from the gripping position to the release position, to leverage abutment wall of the recess 47.
- base body 31 may relative freely rotate the distal body 32 with respect to the base body 31.
- the operator in charge can release lever 43a of the maneuvering element so that return element 42 can quickly return insert 41 (sliding the same along extension path D or along the extension path T) to the gripping position in which tooth 46a of the insert is stably engaged to toothed profile 51.
- insert 41 may be, in a non-limiting way, directly carried by the base body 31. It is not excluded the possibility to arrange an insert 41 directly carried by distal body 32 and slidingly movable with respect to said distal body along the extension path T. In such configuration, the insert 41 would be arranged in proximity of the first end portion 32a of the distal body 32, directly facing a portion of engagement of the base body 31, which would be placed at the second end portion 31b of the base body 31, directly facing the insert 41.
- a vehicle lift 1 for example usable in the automotive industry for servicing various types of vehicles, including: cars, trucks or agricultural vehicles.
- Lift 1 may comprise at least one column 2 extending, in use, along a vertical direction between a base portion 2a and a top portion 2b (see, for example, Figure 1 ).
- Column 2 defines the vertical support element which may be fixed to the ground, for example by means of screw-bolt systems, and configured to support the vehicle above the ground.
- Column 2 may comprise a base plate 20, optionally made of metal, configured to be fixed to the ground and from which a metal support frame 21 emerges.
- the support frame 21 may be hollow to internally accommodate one or more components of the lift 1.
- the support frame 21 may have, along its entire extension, a constant profile cross-section, optionally having a substantially "C" or substantially “V” shaped profile.
- the support frame 21 is made of one or more layers of sheet metal.
- the lift 1 may comprise a single column 2 or a plurality of distinct and spaced apart columns 2.
- Figure 1 illustrates, in a non-limiting way, a lift 1 comprising two columns 2 (a first and a second column): the columns are spaced apart from each other and extend, parallel to each other, along a vertical direction. The columns are spaced apart to allow positioning of at least one vehicle between the columns.
- lift 1 comprises at least one carriage 3 engaged with column 2 and slidingly movable along said column.
- lift 1 includes a carriage 3 for each column 2.
- Carriage 3 carries at least one lift arm 30 suitable for contacting the vehicle and moving it with respect to the ground, for example for allowing an operator to service the vehicle.
- Carriage 3 is mobile along column 2 towards and away from base portion 2a (optionally from the plate 20).
- Carriage 3 carries at least one lift arm 30 according to the above description and/or according to any one of the accompanying claims.
- Lift arm 30 is configured to contact the vehicle to allow lifting and lowering.
- Lift arm 30 is positioned transverse to, for example orthogonal to, column 2.
- Lift arm 30 may be oriented, i.e., movable relative to the carriage by rotation about an axis Y, parallel to the direction of extension of column 2: rotation axis Y may develop outside support frame 21 as, for example, illustrated in Figure 1 .
- carriage 3 includes a coupling portion configured to abut on attachment portion 33 of lift arm 30 to define a hinge-type joint (optionally a flat hinge).
- the axis of rotation Y of lift arm 30 is substantially parallel to axis Z of relative rotation between base body 31 and distal body 32 (see, for example, Figure 2 ).
- Carriage 3 may engage two lift arms 30 (see, for example, Figures 1 and 2 ) both configured to contact a vehicle.
- Lift arms 30 may lie substantially in a single plane orthogonal to the direction of extension of column 2.
- At least one of said lift arms 30 may be orientable, i.e., movable by rotation about a respective axis Y parallel to a column extension direction.
- Lift 1 of Figures 1 and 2 has, in a non-limiting way, a first and second lift arms both being orientable; in addition or alternatively, at least one of the lift arms may be extendable.
- lift 1 may comprise a first and a second column. If lift 1 comprises only one column, then lift 1 also has only one carriage 3.
- Figure 1 shows an exemplary lift 1 having a first and a second column each of which comprises a carriage 3 according to above description. Each carriage 3 is movable along the respective column 2 by action of a movement system of known type, for example by means of one or more hydraulic actuators or by means of a screw-nut system operated by an electric motor 7.
- a column lift is shown having a movement system comprising an electric motor 7 for each column housed inside a specific casing 15 arranged at the top portion 2b of the column 2.
- the process may include a step of orienting distal body 32 with respect to base body 31 to place the distal body at a desired angle with respect to the base body 31.
- the orientation step allows lift arm 30 to properly contact the vehicle (e.g., the vehicle body) without causing any damage to components of the vehicle, such as the battery pack of an electric car (fully hybrid or plug-in car).
- This orientation step may include the following sub-steps:
- the sub-step of arranging the insert 41 in the release position comprises the sub-steps of manually moving lever 43a of maneuvering element 43 such that thrust portion 43b may act on insert 41 to disengage the at least one tooth 46a thereof from the toothed profile 51 of distal body 32.
- the process may proceed with the lifting of the arm 30, for example by moving carriage 3 along the column, by operating electric motor 7: the arm 30, after having contacted the vehicle, lifts the vehicle above the ground.
- Not according to the claimed invention is a process for servicing a vehicle using a lift 1 or a lift arm 30 according to the above description.
- the process may be performed on electric or hybrid vehicles having a battery pack.
- the process may comprise the following steps:
- the orientable lift arms 30 it is possible to arrange the distal body 32 of each arm 30 such that the arms 30 does not interfere with the vehicle body and with the battery pack of the vehicle. In other words, orienting the distal body 32 of each lift arm prevents the arm to obstruct the removal of the battery pack under the vehicle.
- the present invention has considerable advantages over the solution of the state of the art.
- use of an insert 41 movable along the base body 31 and/or the distal body 32 can provides a safe and compact lock system 40 allowing an operator to quickly lock and unlock the base body 31 and the distal body 32.
- elements protruding from the lift arm are minimized thus minimizing risks of inadvertent activation by an operator/vehicle, during lift operations.
- the structure of the lift arm 30 can provide a wide positioning area of the support 5 thanks to the presence of the joint between the base body 31 and the distal body 32, which therefore avoids undesired contacts with car components, for example with the battery pack of electric cars which needs to move along a vertical downward direction under the vehicle: the particular structure of the lift arm therefore can allow easy removal of the battery of an electric vehicle.
Landscapes
- Life Sciences & Earth Sciences (AREA)
- Engineering & Computer Science (AREA)
- Geology (AREA)
- Mechanical Engineering (AREA)
- Structural Engineering (AREA)
- Forklifts And Lifting Vehicles (AREA)
Description
- The present invention relates to a lift arm as well as a vehicle lift and a vehicle lift process using said arm. The present invention may be used in the automotive field for servicing vehicles, e.g., cars, trucks or agricultural vehicles.
- Column lifts comprise one or more vertical support columns each of which carries a carriage provided with a nair of adjustable and/or extendable arms, as shown in the US Patent No.
US 4,825,977 : the ends of the arms comprise height-adjustable pads configured to receive the vehicle to be lifted. The movement of each carriage is performed by electromechanical systems, e.g., an electric motor operating on a mother-screw type system, or by hydraulic cylinders. - U.S. Patent Application No.
US 2020/0079627 A1 describes a two-column lift comprising, for each column, two telescopic lift arms hinged to a carriage vertically movable along the respective column. Each arm extends along a rectilinear direction and terminally carries an adapter configured to contact a vehicle: the adapter is hinged to the arm. Rotation between the adapter and the arm may be locked by a further pin insertable through appropriate holes defined on respective plates of the adapter and the telescopic arm.US 2020/0079627 A1 discloses the preamble ofclaim 1. - US patent application No.
US 2019/0276287 A1 also describes a two-column lift comprising, for each column, a first and a second arm hinged to a carriage vertically movable along the respective column. The first arm may be telescopic and extends along a rectilinear direction; the second arm includes a base body, directly hinged to the carriage, and a distal body hinged to the base body: the distal body includes a height adjustable support configured to contact a vehicle. In detail, the base body and the distal body are equal in length and hinged at an intermediate joint. Relative rotation between the base body and the distal body of the second arm may be locked by a lever carried by the base body engaging a toothed disc on the second arm. - The Applicant observed that lifts of the state of the art are not devoid of limitations and drawbacks. Such lifts have articulated lift arms having a complex, bulky, and difficult to implement rotation lock system; such lock systems are not capable of ensuring rapid and safe locking of the rotation of the articulated arm, a condition which negatively affects on safety and productivity. Although the known lifts are used for lifting vehicles, the Applicant observed that such lifts are not devoid of limitations and drawbacks, therefore being subject to improvement from various points.
- The object of the present invention is to overcome at least one of the drawbacks and/or limitations of the previous solutions.
- An object of the present invention is to provide a lift arm and a respective lift having a simple and compact structure, which has low production costs and which at the same time is structurally robust, and able to safely and quickly lift vehicles. Furthermore, an object of the present invention is to provide a lift arm and a respective vehicle lift capable of guaranteeing the effective and quick lifting of a wide range of transport means. Furthermore, another object of the present invention is to provide a lift capable of operating in a safe and reliable manner, in particular capable of lifting vehicles without damaging said vehicle and/or components of the lift itself.
- These and other objects, which will be more apparent from the following description, are substantially attained by a lift arm and a vehicle lift according to one or more of the attached claims and/or the aspects below.
- Some embodiments and some aspects of the invention will be hereafter described with reference to the attached exemplifying and therefore not-limiting drawings, in which:
-
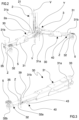
Figure 1 is a perspective view of a lift according to the present invention; -
Figure 2 shows a detail of the lift inFigure 1 ; -
Figure 3 is a perspective view of a lift arm according to the present invention; -
Figure 4 shows a detail of a lift arm according to the present invention; -
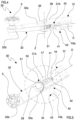
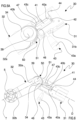
Figures 5 and5A show details of a lift arm according to the present invention where an insert of said lift arm is in grip position; -
Figure 6 is a further view of a detail of a lift arm according to the present invention where an insert of said lift arm is in release position; -
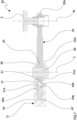
Figures 7 and8 are sectional views of a lift arm according to the present invention. - In the detailed description, corresponding parts illustrated in the various figures are indicated with same reference numbers. The figures could include representations that are not in scale; parts and components illustrated in the figures might be schematic representations.
- The terms "horizontal" or "vertical", used in relation to components of the lift, refer to a condition of use of the lift during which the lift executes, or is usable, for executing raising/lowering of a vehicle.
-
Reference number 30 indicates a lift arm for a vehicle lift. For example, thelift arm 30 may be used in the automotive industry for servicing vehicles, e.g., cars, trucks, agricultural vehicles. Thelift arm 30 is usable in association with at least one column of a vehicle lift to allow lifting of the vehicle with respect to the ground. - The
lift arm 30 includes abase body 31 extending between a first and asecond end portion base body 31 has an elongated conformation; thebase body 31 has a predetermined length defined by the maximum distance between the first and thesecond end portions base body 31 may be, for example, equal to or greater than 500 mm, optionally comprised between 500 mm and 1200 mm. - The length of
base body 31 may be fixed or adjustable. In the accompanying figures, thelift arm 30 is extendable: the distance between the first andsecond end portions Figure 8 ). Theactuator 60 may comprise at least one of: a hydraulic cylinder, a pneumatic cylinder, an electric motor. - In particular, the
base body 31 may have a first section and a second section, which are movable with respect to each other along the extension path D of thebase body 31 to adjust a length of thebase body 31. For example, the first section may extend from thefirst end portion 31a to a centerline portion of thebase body 31 while the second section may extend from thesecond end portion 31b to the centerline portion of thebase body 31. - The
actuator 60 may be engaged, on one side, to the first section and, on the other side, to the second section: activation of theactuator 60 allows to approach or move away the first andsecond end portions - For example, the
base body 31 may be at least partly hollow and internally define a housing compartment A suitable for at least partly receiving said actuator 60: in such a configuration, theactuator 60 would be at least partly hidden within thebase body 31. - In particular, both the first section and the second section of the
base body 31 may be hollow and internally define a respective housing compartment (Figure 8 ); the second section of thebase body 31 may be placed at least partially within the first section and be slidingly movable at least partially within said first section of thesame base body 31. Theactuator 60 is arranged within the housing compartments defined by the first and second sections of the base body 31: the housing compartments of the first and second sections of thebase body 31 communicate with each other and cooperate to define a single housing compartment A of the base body 31 (Figure 8 ). From a structural point of view, thebase body 31 may present a box shape, for example, the base body may have a cross section, in plane orthogonal to the extension path D of thebase body 31, having substantially square or rectangular shape. Such cross section may be constant along the entire extension of the base body or it may get smaller moving towards the second end portion. In particular, the first section of the base body may have cross section greater than the cross section of the second section of thesame base body 31; in this way, the first section may internally receive the second section of the base body and guide movement of the second section of thesame base body 31. Obviously, the possibility of fixed, non-extendable,base body 31 is not excluded. - As shown in
Figure 8 , thebase body 31 may comprise at least oneattachment portion 33 configured for engagement of thelift arm 30 to at least onecarriage 3 of a lift 1 (seeFigures 1 and2 ). Theattachment portion 33 may comprise at least one plate suitable for being hinged, for example by means of a cylindrical pin, to acarriage 3 of a lift, such that the lift arm may rotate with respect to the carriage about an axis Y, in particular orthogonal to the extension path of thebase body 31. - At the
second end portion 31b, thebase body 31 comprises an engagement portion coupling thebase body 31 with adistal body 32 of thesame lift arm 30. In particular, the engagement portion of thebase body 31 comprises at least one plate 35 (seeFigures 4 and7 ) having at least one through hole for receiving acylindrical pin 39 configured to engage thebase body 31 and thedistal body 32. In detail, the engagement portion of thebase body 31 comprises twoplates 35 spaced apart from each other, each of which has at least one through hole suitable to receive thecylindrical pin 39. The plate(s) 35 define thesecond end portion 31b of thebase body 31 receiving and engaging thedistal body 32. - The
distal body 32 extends between a first and asecond end portions Figures 6 and8 ). In detail, thedistal body 32 has an elongated conformation; thedistal body 32 has a length defined by the maximum distance between the first andsecond end portions base body 31 is greater than the length of thedistal body 32; for example, the ratio between the length of thebase body 31 and the length of thedistal body 32 may be greater than 3, and optionally between 4 and 8. - The
base body 31 and thedistal body 32 may relatively rotate at least around an axis Z. Thedistal body 32 is hinged to thebase body 31 at thesecond end portion 31b. In detail, thebase body 31 and thedistal body 32 are hinged at thesecond end portion 31b of thebase body 31 and at thefirst end portion 32a of thedistal body 32. Thedistal body 32 is thus a movable extension of thebase body 31. The Z-axis of relative rotation between thebase body 31 and thedistal body 32 is orthogonal to the extension path D of thebase body 31, in particular, the Z-axis may be orthogonal to both extension paths D and T respectively ofbase body 31 anddistal body 32. In detail, thebase body 31 is coupled to thedistal body 32 by a flat hinge allowing only the relative rotation of thebodies - In greater detail, the
base body 31 and thedistal body 32 are movable at least between: - an aligned position (
Figures 3-5 and8 ) where the extension paths D, T respectively ofbase body 31 anddistal body 32, are substantially parallel to each other, - an offset position (
Figures 2 and6 ) where the extension paths D, T respectively ofbase body 31 anddistal body 32, are angularly offset from each other. - In the offset position, the extension paths D, T intersect and essentially define an ideal plane; the axis Z of rotation of
base body 31 relative todistal body 32 is orthogonal to said ideal plane. In the aligned position, thebase body 31 and thedistal body 32 define a maximum length of thelift arm 30, which is therefore defined by the maximum distance between thesecond end portion 32b of thedistal body 32 and thefirst end portion 31a of thebase body 31; this maximum length may be equal to or greater than 600 mm, optionally comprised between 600 mm and 2000 mm. Thedistal body 32 comprises, at thefirst end portion 32a, a respective engagement portion coupled with the engagement portion of thebase body 31. In detail, the engagement portion of thedistal body 32 comprises at least oneplate 34 at least partially overlappingplate 35 of thebase body 31. In greater detail, the embodiment in which thebase body 31 has two spaced apartplates 35,plate 34 of thedistal body 32 is placed between said twoplates 35.Plate 34 of thedistal body 32 comprises a respective through hole aligned with the at least one through hole ofplate 35 of thebase body 31. Thebase body 31 is engaged to thedistal body 32 by cylindrical pin 39 (Figure 4 ) which crosses the through-holes of therespective plates -
Lift arm 30 may further comprise at least onesupport 5 carried by thedistal body 32 and configured to directly contact the vehicle. In detail, thesupport 5 is arranged at thesecond end portion 32b of thedistal body 32 and protrudes from the distal body along a direction which is transverse, optionally orthogonal, to the extension path T of the distal body (in particular orthogonally to the ideal plane defined by the extension paths D and T of thebase body 31 and the distal body 32).Support 5 may move relative to thedistal body 32 towards to and away from the ideal plane. As schematically shown infigure 7 , also support 5 may freely rotate, with respect todistal body 32 about an own axis W; axis W may be substantially parallel to axis Z of rotation of thebase body 31 relative thedistal body 32. -
Lift arm 30 further comprises alock system 40 configured to block relative rotation between thebase body 31 and thedistal body 32. Thebase body 31 and thedistal body 32 are movable with respect to each other such that thedistal body 32 may be oriented to properly contact the vehicle without causing damage to vehicle parts, for example to a vehicle battery pack; after having properly orientated thedistal body 32, the relative position between thedistal body 32 and thebase body 31 may be locked to provide the lift arm with a certain stability and to avoid undesired movements that could cause the vehicle roll overlift arm 30. Thelock system 40 comprises at least oneinsert 41 movable at least between: - a release position (see, for example,
Figure 6 ) whereinsert 41 is configured for allowing relative rotational between thebase body 31 and thedistal body 32, and - a gripping position (see, for example,
Figures 5 ,5A and7 ) whereinsert 41 is configured for blocking relative rotational between thebase body 31 and thedistal body 32. -
Insert 41 is carried by at least one of saidbase body 31 and saiddistal body 32 and it is slidingly movable with respect to said bodies between the gripping position and the release position, and vice versa along at least a trajectory substantially parallel to at least one section of at least one of the extension path D of thebase body 31 and the extension path T of thedistal body 32. - In the accompanying figures, a non-limiting example of an
insert 41 carried directly by thebase body 31 is shown: theinsert 41 is slidingly movable between the gripping position and the release position, and vice versa, along a trajectory substantially parallel to the extension path D of thebase body 31. - The
insert 41 has a substantially parallelepiped, optionally rectangular parallelepiped, shape, and longitudinally extends between ahead surface 40b facing thedistal body 32, and abottom surface 40a facing thefirst end portion 31a of thesame base body 31 carrying theinsert 41. In such configuration, the insert 41 (carried by the base body 31) has anengagement portion 46 which, in the gripping position, is configured to constrain anengagement portion 50 of the distal body 32: theengagement portion 46 of theinsert 41 emerges from thehead surface 40b in the direction of thedistal body 32. Theengagement portion 46 of theinsert 41 may comprise at least one tooth 46a configured to cooperate with atoothed profile 51 of theengagement portion 50 of thedistal body 32; in particular, theengagement portion 46 of theinsert 41 may comprise a plurality of teeth 46a (Figure 6 ) configured to cooperate with thetoothed profile 51 of theengagement portion 50 of thedistal body 32. The teeth 46a of theengagement portion 46 may be aligned along a direction which is transverse, optionally orthogonal, to the movement direction of theinsert 41, namely being aligned according to an alignment direction, which is orthogonal to the extension path D of thebase body 31 and parallel to the ideal plane. In detail, as shown in the accompanying figures, thehead surface 40b may be flat: the plurality of teeth 46a may emerge from saidflat head surface 40b. - It is not excluded the possibility of a
curved head surface 40b: in such configuration, the plurality of teeth 46a of theinsert 41 would be aligned along an arc profile such that said teeth 46a may essentially define a portion of a toothed wheel suitable to engage thetoothed profile 51 of thedistal body 32. For example, theinsert 41 may have a number of teeth 46a equal to or greater than 2, optionally between 3 and 5. - Similarly, the
toothed profile 51 of theengagement portion 50 of thedistal body 32 may comprise, in a non-limiting way, a plurality of teeth aligned along a respective arc shaped trajectory; the plurality of teeth of theengagement portion 50 of thedistal body 32, in the gripping position of theinsert 41, is configured to cooperate with the at least one tooth 46a of theengagement portion 46 of theinsert 41 to block relative rotation between thebase body 31 and thedistal body 32. The arc-shaped trajectory of alignment of the teeth oftoothed profile 51 lies in a plane substantially parallel to the ideal plane. In detail, thetoothed profile 51 is defined at thefirst end portion 32a and is directed towards thebase body 31; thetoothed profile 51 emerges substantially from a curved end surface ofdistal body 32 and therefore directly faces tooth 46a of insert 41 (see, for example, the detailFigures 5A and 6 ). However, the use of atoothed profile 51 extending along a rectilinear trajectory, i.e., emerging towards thebase body 31 from a flat end surface of the distal body 32 (condition not illustrated), is not excluded. - The
insert 41 may be placed at an external surface of thebase body 31 or integrated within thebase body 31. Theinsert 41 is placed, in a non-limiting way, within aseat 44 of the base body 31 (Figures 5-6 ). Theseat 44 is placed at thesecond end portion 31b and has a substantially "U" shape, with concavity directed towards the distal body 32: theseat 44 of thebase body 31 is open. In fact, theseat 44 is at least partially counter-shaped to theinsert 41 so that the insert is guided in its movement between the release position and the gripping position, and vice versa. - As can be seen for example from
Figure 6 , insert 41, at least in the release position, is entirely housed in theseat 44 of thebase body 31. In the gripping position, thehead surface 40b of theinsert 41 is placed near a front free edge of said seat: the at least one tooth 46a (optionally the plurality of teeth 46a) ofinsert 41, in the gripping position, at least partially protrudes fromseat 44 to contact thetoothed profile 51 of the distal body. - The
lock system 40 may comprise areturn element 42 configured to thrust on theinsert 41 and force it to normally stay in the gripping position. In fact, thereturn element 42 is configured to normally keepinsert 41 in the gripping position whereinsert 41 is constrained to theengagement portion 50 of thedistal body 32 to thereby prevent relative rotation between thebase body 31 and thedistal body 32. - In detail, the
return element 42, on one side, contacts thebase body 31 and, on the other side, contacts theinsert 41 to keep the insert normally in the gripping position. In greater detail,return element 42 is placed entirely insideseat 44 between a bottom wall of theseat 44 and thebottom wall 40a of the insert: the return element pushes the bottom ofinsert 41 to force the engagement of tooth 46a withtoothed profile 51 of thedistal body 32. Thereturn element 42 may be an elastic return element and may comprise at least one of: a torsion spring, a compression spring, a tension spring, an air spring, a leaf spring. In the accompanying figures, the return element comprises, in a non-limiting way, a compression spring, on one side, resting on the bottom wall of the seat (wall directly facing thebottom surface 40a of the insert 41), and, on the opposite side, at least partially housed inside a guide seat onbottom surface 40a of theinsert 41. It is not excluded the possibility of using adifferent return element 42, for example an actuator comprising at least one of: a magnetic or electromagnetic actuator, a hydraulic actuator, or a pneumatic actuator. - The
insert 41 may be moved from the gripping position to the release position by an operator manual action or by an actuator, for example comprising at least one of: a magnetic or electromagnetic actuator, a hydraulic actuator or a pneumatic actuator.Lift arm 30 may also comprise at least onemaneuvering element 43 engaged to theinsert 41 and emerging from at least one of thebase body 31 and thedistal body 32; themaneuvering element 43 is configured to be manually operated to move theinsert 41 at least between the gripping position and the release position. In detail, themaneuvering element 43 includes apush portion 43b directly engaged to theinsert 41 and alever 43a allowing an operator to impose a movement to theinsert 41 at least between the gripping position and the release position. - In detail, the
insert 41 may comprise at least oneseat 41a (Figure 7 ) within which thethrust portion 43b of themaneuvering element 43 is engaged.Seat 41a may have a cylindrical shape whereas thethrust portion 43b of themaneuvering element 43 may comprise a cylindrical pin at least partially counter-shaped toseat 41a. Thethrust portion 43b is displaced thanks to manual intervention of the operator, from outside thebase body 31, onlever 43a: displacement of thethrust portion 43b allows guiding the sliding insert from the gripping position to the release position to allow consequent disengagement of tooth 46a fromtoothed profile 51. -
Figure 5A shows themaneuvering element 43 which, in addition to being engaged in the insert, may further have asupport end 43c allowing the maneuvering element to engage thebase body 31. In detail, thebase body 31 has arecess 47 delimited by at least one abutment wall;recess 47 is placed at the side ofseat 44 of the same base body 31:recess 47 andseat 44 ofbase body 31 are in communication with each other and define a single pocket suitable to receiveinsert 41 and at least part of maneuvering element 43 (see, for example,Figure 5A ). Thesupport end 43c of maneuveringelement 43 opposed to thelever 43a and it is configured to be positioned within the recess, resting against the abutment wall to allow an operator, during (optionally manual) movement of themaneuvering element 43 from the gripping position to the release position, to leverage abutment wall of therecess 47. Following operation of thelever 43a and movement ofinsert 41 from the gripping position to the release position,base body 31 may relative freely rotate thedistal body 32 with respect to thebase body 31. Once the desired orientation of thedistal body 32 relative to thebase body 31 has been reached, the operator in charge can releaselever 43a of the maneuvering element so thatreturn element 42 can quickly return insert 41 (sliding the same along extension path D or along the extension path T) to the gripping position in which tooth 46a of the insert is stably engaged totoothed profile 51. - As mentioned above, in the accompanying figured, insert 41 may be, in a non-limiting way, directly carried by the
base body 31. It is not excluded the possibility to arrange aninsert 41 directly carried bydistal body 32 and slidingly movable with respect to said distal body along the extension path T. In such configuration, theinsert 41 would be arranged in proximity of thefirst end portion 32a of thedistal body 32, directly facing a portion of engagement of thebase body 31, which would be placed at thesecond end portion 31b of thebase body 31, directly facing theinsert 41. - It is also an aspect of the present invention a
vehicle lift 1, for example usable in the automotive industry for servicing various types of vehicles, including: cars, trucks or agricultural vehicles. -
Lift 1 may comprise at least onecolumn 2 extending, in use, along a vertical direction between abase portion 2a and atop portion 2b (see, for example,Figure 1 ).Column 2 defines the vertical support element which may be fixed to the ground, for example by means of screw-bolt systems, and configured to support the vehicle above the ground.Column 2 may comprise abase plate 20, optionally made of metal, configured to be fixed to the ground and from which ametal support frame 21 emerges. Thesupport frame 21 may be hollow to internally accommodate one or more components of thelift 1. Thesupport frame 21 may have, along its entire extension, a constant profile cross-section, optionally having a substantially "C" or substantially "V" shaped profile. In detail, thesupport frame 21 is made of one or more layers of sheet metal. - The
lift 1 may comprise asingle column 2 or a plurality of distinct and spaced apartcolumns 2.Figure 1 illustrates, in a non-limiting way, alift 1 comprising two columns 2 (a first and a second column): the columns are spaced apart from each other and extend, parallel to each other, along a vertical direction. The columns are spaced apart to allow positioning of at least one vehicle between the columns. - As shown in
Figure 1 ,lift 1 comprises at least onecarriage 3 engaged withcolumn 2 and slidingly movable along said column. In detail,lift 1 includes acarriage 3 for eachcolumn 2.Carriage 3 carries at least onelift arm 30 suitable for contacting the vehicle and moving it with respect to the ground, for example for allowing an operator to service the vehicle.Carriage 3 is mobile alongcolumn 2 towards and away frombase portion 2a (optionally from the plate 20). -
Carriage 3 carries at least onelift arm 30 according to the above description and/or according to any one of the accompanying claims.Lift arm 30 is configured to contact the vehicle to allow lifting and lowering.Lift arm 30 is positioned transverse to, for example orthogonal to,column 2.Lift arm 30 may be oriented, i.e., movable relative to the carriage by rotation about an axis Y, parallel to the direction of extension of column 2: rotation axis Y may developoutside support frame 21 as, for example, illustrated inFigure 1 . In detail,carriage 3 includes a coupling portion configured to abut onattachment portion 33 oflift arm 30 to define a hinge-type joint (optionally a flat hinge). The axis of rotation Y oflift arm 30 is substantially parallel to axis Z of relative rotation betweenbase body 31 and distal body 32 (see, for example,Figure 2 ). -
Carriage 3 may engage two lift arms 30 (see, for example,Figures 1 and2 ) both configured to contact a vehicle. Liftarms 30 may lie substantially in a single plane orthogonal to the direction of extension ofcolumn 2. At least one of saidlift arms 30 may be orientable, i.e., movable by rotation about a respective axis Y parallel to a column extension direction.Lift 1 ofFigures 1 and2 has, in a non-limiting way, a first and second lift arms both being orientable; in addition or alternatively, at least one of the lift arms may be extendable. - As specified above,
lift 1 may comprise a first and a second column. Iflift 1 comprises only one column, then lift 1 also has only onecarriage 3.Figure 1 shows anexemplary lift 1 having a first and a second column each of which comprises acarriage 3 according to above description. Eachcarriage 3 is movable along therespective column 2 by action of a movement system of known type, for example by means of one or more hydraulic actuators or by means of a screw-nut system operated by anelectric motor 7. InFigure 1 , a column lift is shown having a movement system comprising anelectric motor 7 for each column housed inside aspecific casing 15 arranged at thetop portion 2b of thecolumn 2. - It is also an aspect not according to the claimed invention a process for lifting vehicles using a
lift 1 according to the above description. The process involves the following steps: - arranging
carriage 3 in proximity to the ground, for example operatingelectric motor 7 and causing sliding of thecarriage 3 alongcolumn 2. Such phase allows to bring thelift arm 30 at the ground; - placing a vehicle above the at least one
lift arm 30, - moving
carriage 3 alongcolumn 2 to bring the at least onelift arm 30 into contact with the vehicle to lift the vehicle above the ground. - Following placing of the vehicle above the
lift arm 30 and prior to contacting the vehicle with thearm 30, the process may include a step of orientingdistal body 32 with respect tobase body 31 to place the distal body at a desired angle with respect to thebase body 31. The orientation step allowslift arm 30 to properly contact the vehicle (e.g., the vehicle body) without causing any damage to components of the vehicle, such as the battery pack of an electric car (fully hybrid or plug-in car). - This orientation step may include the following sub-steps:
- arranging
insert 41 oflock system 40 in the release position, - rotating
distal body 32 with respect tobase body 31 about the respective axis Z to arrange said distal body at a desired angle with respect to thebase body 31, - arranging
insert 41 oflock system 40 in the gripping position to lock saiddistal body 32 andbase body 31 at the desired angle; this step may be performed byreturn element 42 following release oflever 43. - The sub-step of arranging the
insert 41 in the release position comprises the sub-steps of manually movinglever 43a of maneuveringelement 43 such thatthrust portion 43b may act oninsert 41 to disengage the at least one tooth 46a thereof from thetoothed profile 51 ofdistal body 32. - After having correctly oriented the
distal body 32 and thebase body 31, the process may proceed with the lifting of thearm 30, for example by movingcarriage 3 along the column, by operating electric motor 7: thearm 30, after having contacted the vehicle, lifts the vehicle above the ground. - Not according to the claimed invention is a process for servicing a vehicle using a
lift 1 or alift arm 30 according to the above description. - The process may be performed on electric or hybrid vehicles having a battery pack. In such configuration, the process may comprise the following steps:
- lifting the vehicle, for example by the process described above,
- removing the battery pack from the vehicle,
- lowering the battery pack maintaining it within a volume comprised between the
lift arms 30 and each column without interfering with the arm. Such step being performed moving the battery pack along a substantially vertical path. - In fact, thanks to the
orientable lift arms 30 it is possible to arrange thedistal body 32 of eacharm 30 such that thearms 30 does not interfere with the vehicle body and with the battery pack of the vehicle. In other words, orienting thedistal body 32 of each lift arm prevents the arm to obstruct the removal of the battery pack under the vehicle. - The present invention has considerable advantages over the solution of the state of the art. In particular, use of an
insert 41 movable along thebase body 31 and/or thedistal body 32 can provides a safe andcompact lock system 40 allowing an operator to quickly lock and unlock thebase body 31 and thedistal body 32. In fact, as the insert moves alongbase body 31, elements protruding from the lift arm are minimized thus minimizing risks of inadvertent activation by an operator/vehicle, during lift operations. - Moreover, the structure of the
lift arm 30 can provide a wide positioning area of thesupport 5 thanks to the presence of the joint between thebase body 31 and thedistal body 32, which therefore avoids undesired contacts with car components, for example with the battery pack of electric cars which needs to move along a vertical downward direction under the vehicle: the particular structure of the lift arm therefore can allow easy removal of the battery of an electric vehicle.
Claims (15)
- Lift arm (30) for vehicle lift (1), said lift arm (30) comprising:- at least one base body (31) extending between a first end portion (31a) and a second end portion (31b) along an extension path (D),- at least one distal body (32) extending between a respective first end portion (32a) and a second end portion (32b) along a respective extension path (T), wherein the distal body (32) is rotatably mounted to the base body (31) about at least one axis (Z),- at least one lock system (40) configured to block the relative rotation between the base body (31) and the distal body (32), said lock system (40) comprising at least one insert (41) movable at least between:characterized by the fact that the insert (41) of the lock system (40) is carried by at least one of said base body (31) and distal body (32), wherein the insert (41) is slidingly movable with respect to at least one of said base body and distal body between the gripping position and the release position, and vice versa, along at least one trajectory substantially parallel to at least one section of at least one of said extension path (D) of the base body (31) and said extension path (T) of the distal body (32).∘ a release position where said insert (41) is configured to allow relative rotation between the base body (31) and the distal body (32), and∘ a gripping position where said insert (41) is configured to block relative rotation between the base body (31) and the distal body (32),
- Lift arm of claim 1, wherein the base body (31) and the distal body (32) are hinged at the second end portion (31b) of the base body (31) and at the first end portion (32a) of the distal body (32),
wherein the axis (Z) of relative rotation between the base body (31) and the distal body (32) is orthogonal both to the extension paths (D, T) of the base body (31) and the distal body (32). - Lift arm according to any one of the preceding claims, wherein the base body (31) and the distal body (32) are movable at least between:- an aligned position where the extension paths (D, T) respectively of the base body (31) and the distal body (32) are substantially parallel to each other,- an offset position where the extension paths (D, T) respectively of the base body (31) and the distal body (32) are angularly offset from each other.
- Lift arm according to any one of the preceding claims, wherein the extension paths (D, T) respectively of the base body (31) and the distal body (32), in the offset position, intersect on an ideal plane,
wherein the axis (Z) of relative rotation between the base body (31) and the distal body (32) is orthogonal to said ideal plane. - Lift arm according to any one of the preceding claims, wherein the insert (41) is carried by the base body (31),
wherein the insert (41) is slidingly movable between the gripping position and the release position, and vice versa, along a trajectory parallel to the extension path (D) of the base body (31). - Lift arm according to any one of the preceding claims, wherein the insert (41) comprises at least one engagement portion (46), wherein the distal body (32) comprises a respective engagement portion (50),
wherein the engagement portion (46) of the insert (41), in the gripping position, is configured to constrain the engagement portion (50) of the distal body (32) to block relative rotation between said distal body and the base body (31). - Lift arm of the preceding claim, wherein the engagement portion (46) of the insert (41) comprises at least one tooth (46a) configured to cooperate with a toothed profile (51) of the engagement portion (50) of the distal body (32),
wherein the toothed profile (51) is defined at the first end portion (32a) of the distal body (32) and faces the base body (31). - Lift arm of the preceding claim, wherein the toothed profile (51) of the engagement portion (50) of the distal body (32) comprises a plurality of teeth aligned along a circular arc trajectory and configured to cooperate with the at least one tooth of the engagement portion (46) of the insert (41) to block relative rotation between the base body (31) and the distal body (32).
- Lift arm of claim 7 or 8, wherein the engagement portion (46) of the insert (41) comprises a plurality of teeth (46a) configured to cooperate with the toothed profile (51) of the distal body (32), wherein the teeth of the plurality of teeth (46a) of the engagement portion (46) of the insert (41) are aligned along a direction transversal, optionally orthogonal, with respect to the movement direction of the insert (41).
- Lift arm according to any one of the preceding claims, wherein the lock system (40) comprises at least one return element (42) in contact, on one side, with the base body (31) and, on another side, with the insert (41), wherein the return element (42) is configured to maintain the insert (41) in the gripping position.
- Lift arm of the preceding claim, wherein the return element (42) comprises at least one of: a torsion spring, a compression spring, a tension spring, a pneumatic spring, and a leaf spring.
- Lift arm according to any one of the preceding claims, wherein the base body (31) comprises, at the second end portion (31b), a seat (44), wherein the insert (41) is slidingly movable in the seat (44).
- Lift arm of the preceding claim, wherein the seat (44) has a profile with concavity directed towards the distal body (32), wherein the insert (41) is at least partially counter-shaped to the seat (44) of the base body (31).
- Lift arm according to any one of the preceding claims, wherein the lock system (40) comprises at least one maneuvering element (43) engaged to the insert (41) and emerging from at least one of said base body (31) and distal body (32), said maneuvering element (43) being configured to move the insert (41) at least between the gripping position and the release position.
- A vehicle lift (1) comprising:- at least one column (2) extending, in use, along a vertical direction (V),- at least one carriage (3) engaged to the column (2) and slidingly movable along said column,- at least one lift arm (30) according to any one of the preceding claims carried by the carriage.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP25180407.6A EP4631904A1 (en) | 2021-10-25 | 2022-09-27 | Lift arm and vehicle lift |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US17/509,307 US12030756B2 (en) | 2021-10-25 | 2021-10-25 | Vehicle lift |
| IT202200006410 | 2022-03-31 |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP25180407.6A Division EP4631904A1 (en) | 2021-10-25 | 2022-09-27 | Lift arm and vehicle lift |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP4169867A1 EP4169867A1 (en) | 2023-04-26 |
| EP4169867B1 true EP4169867B1 (en) | 2025-06-18 |
Family
ID=83506402
Family Applications (2)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP25180407.6A Pending EP4631904A1 (en) | 2021-10-25 | 2022-09-27 | Lift arm and vehicle lift |
| EP22198153.3A Active EP4169867B1 (en) | 2021-10-25 | 2022-09-27 | Lift arm and vehicle lift |
Family Applications Before (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP25180407.6A Pending EP4631904A1 (en) | 2021-10-25 | 2022-09-27 | Lift arm and vehicle lift |
Country Status (2)
| Country | Link |
|---|---|
| EP (2) | EP4631904A1 (en) |
| ES (1) | ES3041034T3 (en) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US11667501B2 (en) * | 2018-08-29 | 2023-06-06 | Mohawk Lifts, LLC | Two-post vehicle lift and adapter system for material, handling vehicles |
Family Cites Families (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0512239Y2 (en) * | 1987-11-10 | 1993-03-29 | ||
| DE102018105573A1 (en) | 2018-03-12 | 2019-09-12 | Otto Nussbaum Gmbh & Co. Kg | LIFTING STATION FOR MOTOR VEHICLES |
| US11667501B2 (en) | 2018-08-29 | 2023-06-06 | Mohawk Lifts, LLC | Two-post vehicle lift and adapter system for material, handling vehicles |
-
2022
- 2022-09-27 EP EP25180407.6A patent/EP4631904A1/en active Pending
- 2022-09-27 ES ES22198153T patent/ES3041034T3/en active Active
- 2022-09-27 EP EP22198153.3A patent/EP4169867B1/en active Active
Also Published As
| Publication number | Publication date |
|---|---|
| ES3041034T3 (en) | 2025-11-06 |
| EP4169867A1 (en) | 2023-04-26 |
| EP4631904A1 (en) | 2025-10-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US12030756B2 (en) | Vehicle lift | |
| US7677582B2 (en) | Vehicular component apparatus | |
| US6687971B2 (en) | Vehicle body transfer machine and method thereof | |
| JP2022533944A5 (en) | ||
| EP3159298B1 (en) | Lift device for vehicle | |
| US10898396B2 (en) | Loading system | |
| EP4631904A1 (en) | Lift arm and vehicle lift | |
| CN114096482A (en) | Device for lifting a load | |
| CA2784290A1 (en) | Vehicular body assembly locking apparatus and method | |
| CN109476470B (en) | Rail-mounted lift platforms for vehicles and lift mechanisms for rail-mounted lift platforms | |
| WO1995015225A1 (en) | Device for use in conjunction with the straightening of a frame of an automobile | |
| CA2737816C (en) | Mobile jack with locking assembly | |
| JP6504654B2 (en) | Wheel mounting jig | |
| KR102511515B1 (en) | Mobile lift for car maintenance | |
| CN219116959U (en) | Automobile body hoist | |
| CN212607638U (en) | Transfer trolley stop | |
| CN222556436U (en) | Vehicle crane with adjustable cat ladder | |
| US6435785B1 (en) | Vehicle transporter having resiliently-biased locking system | |
| JP3728003B2 (en) | Car lift equipment | |
| CN220427278U (en) | Cross welding operation equipment | |
| JP2585731B2 (en) | Power supply device for mobile vehicles | |
| JP3728004B2 (en) | Car lift equipment | |
| JP2830271B2 (en) | Attachment of forklift | |
| CN219383952U (en) | Heavy holding tool capable of switching different sizes | |
| CN220721058U (en) | Anti-toppling rail grabbing device for ladder vehicle and ladder vehicle |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| P01 | Opt-out of the competence of the unified patent court (upc) registered |
Effective date: 20230515 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20231023 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20250109 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602022016021 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: FP |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250926 Year of fee payment: 4 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250919 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250918 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: NL Payment date: 20250925 Year of fee payment: 4 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20250925 Year of fee payment: 4 Ref country code: AT Payment date: 20251020 Year of fee payment: 4 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250918 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 3041034 Country of ref document: ES Kind code of ref document: T3 Effective date: 20251106 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20251020 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MK05 Ref document number: 1804044 Country of ref document: AT Kind code of ref document: T Effective date: 20250618 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20251018 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20250930 Year of fee payment: 4 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20251015 Year of fee payment: 4 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: W10 Free format text: ST27 STATUS EVENT CODE: U-0-0-W10-W00 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260304 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602022016021 Country of ref document: DE |
|
| RAP2 | Party data changed (patent owner data changed or rights of a patent transferred) |
Owner name: VEHICLE SERVICE GROUP ITALY S.R.L. |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250618 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: L10 Free format text: ST27 STATUS EVENT CODE: U-0-0-L10-L00 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260430 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: H13 Free format text: ST27 STATUS EVENT CODE: U-0-0-H10-H13 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260504 |