EP3207998B1 - Lackierung anlage und anwendungsverfahren - Google Patents
Lackierung anlage und anwendungsverfahren Download PDFInfo
- Publication number
- EP3207998B1 EP3207998B1 EP17157046.8A EP17157046A EP3207998B1 EP 3207998 B1 EP3207998 B1 EP 3207998B1 EP 17157046 A EP17157046 A EP 17157046A EP 3207998 B1 EP3207998 B1 EP 3207998B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- dispensing devices
- spray
- supporting frame
- robot
- spray dispensing
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images







Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B13/00—Machines or plants for applying liquids or other fluent materials to surfaces of objects or other work by spraying, not covered by groups B05B1/00 - B05B11/00
- B05B13/02—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work
- B05B13/0221—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work characterised by the means for moving or conveying the objects or other work, e.g. conveyor belts
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B15/00—Details of spraying plant or spraying apparatus not otherwise provided for; Accessories
- B05B15/60—Arrangements for mounting, supporting or holding spraying apparatus
- B05B15/65—Mounting arrangements for fluid connection of the spraying apparatus or its outlets to flow conduits
- B05B15/652—Mounting arrangements for fluid connection of the spraying apparatus or its outlets to flow conduits whereby the jet can be oriented
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B1/00—Nozzles, spray heads or other outlets, with or without auxiliary devices such as valves, heating means
- B05B1/02—Nozzles, spray heads or other outlets, with or without auxiliary devices such as valves, heating means designed to produce a jet, spray, or other discharge of particular shape or nature, e.g. in single drops, or having an outlet of particular shape
- B05B1/04—Nozzles, spray heads or other outlets, with or without auxiliary devices such as valves, heating means designed to produce a jet, spray, or other discharge of particular shape or nature, e.g. in single drops, or having an outlet of particular shape in flat form, e.g. fan-like, sheet-like
Definitions
- the method further advantageously provides that the base of the anthropomorphous robot is arranged upstream of the spray dispensing devices with respect to the direction and way of paint dispensation by the spray dispensing devices.
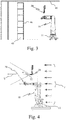
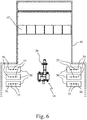
- FIG. 3 a possible embodiment is illustrated of a plant according to the invention, wherein the robot 10 and the spray dispensing devices 20 are housed in a chamber 40 isolated with respect to the outer environment.
- the plant comprises in particular a drawing apparatus 45 with drawing openings 46 to draw the air flow, which are facing the spray-painting devices 20.
- the base 11 of the robot 10 is arranged upstream of the spray dispensing devices 20 also with respect to the direction and way of the airflow drawn by the drawing apparatus 45.
- the plant comprises deposit stations 50 provided for example with vertical pins 55 on which the frames 30 can be deposited by fitting the hollow element 35 integral with the post 33 on one of the pins 55.
- the deposit stations 50 are arranged in positions reachable by the robot 10 to allow the robot to rest the supporting frames 30 at the end of a painting step, as well as to pick them up the moment they have to be subjected to the application of further paint layers once again, for example in order to apply a second hand of the same paint or to apply a paint different from the last applied layer.
- the deposit stations 50 are preferably movable and can be manually moved, otherwise automatically along an endless chain for moving the deposit stations 50.
Landscapes
- Spray Control Apparatus (AREA)
- Details Or Accessories Of Spraying Plant Or Apparatus (AREA)
Claims (15)
- Eine Lackieranlage umfassend mindestens einen Trägerrahmen (30) für zu lackierende Teile, eine oder mehrere auf einer festen Struktur (21) installierte Sprühlack-Auftragsvorrichtungen (20, 20', 20") und einen sechsachsigen anthropomorphen Roboter (10), an dessen Ende lösbare Eingriffsmittel (13, 14) angebracht sind, um den mindestens einen Trägerrahmen (30) in Bezug auf die Sprühauftragsvorrichtungen (20, 20', 20") zu bewegen, während Teile bemalt werden, gekennzeichnet durch eine Absaugvorrichtung (45) mit Absaugöffnungen (46) zum Absaugen des Luftstroms, die den Sprühauftragsvorrichtungen (20, 20', 20") zugewandt sind, wobei die Basis (11) des anthropomorphen Roboters (10) stromaufwärts der Sprühauftragsvorrichtungen (20, 20', 20") in Bezug auf die Richtung und den Weg des Luftstroms, der von der Absaugvorrichtung (45) abgezogen wird, angeordnet ist, und dadurch, dass die Basis (11) des anthropomorphen Roboters (10) in Bezug auf die Richtung und den Weg der Farbabgabe durch die Sprühauftragsvorrichtungen (20, 20', 20") stromaufwärts von den Sprühauftragsvorrichtungen (20, 20', 20") angeordnet ist.
- Die Anlage gemäß Anspruch 1, wobei eine Abschirmung (17) senkrecht zur Drehachse des Handgelenks des anthropomorphen Roboters (10) angebracht ist, um die Gelenkverbindung des anthropomorphen Roboters (10) zu schützen.
- Die Anlage gemäß Anspruch 1, wobei die lösbaren Eingriffsmittel (13, 14) einen Stift (13) umfassen, der in einen hohlen Pfosten (33) des mindestens einen Trägerrahmens (30) eingepasst werden kann, wobei der Stift (13) und der Pfosten (33) Achsen aufweisen, die mit der Drehachse des Handgelenks des anthropomorphen Roboters (10) ausgerichtet und koplanar dazu sind, wenn der mindestens eine Trägerrahmen (30) mit dem anthropomorphen Roboter (10) in Eingriff steht und die Abgabe von Sprühlack aktiviert ist.
- Die Anlage gemäß Anspruch 1, gekennzeichnet durch eine oder mehrere Ablagestationen (50), die mit Hakenmitteln (55) versehen sind, um den mindestens einen Trägerrahmen (30) abzulegen, wenn dieser von dem anthropomorphen Roboter (10) freigegeben wird, und/oder um den mindestens einen Trägerrahmen (30) durch den anthropomorphen Roboter (10) aufzunehmen.
- Die Anlage gemäß Anspruch 4, wobei der Trägerrahmen (30) mindestens ein Element (35) aufweist, das mit dem Pfosten (33) einstückig ist, um mit den Hakenmitteln (55) der einen oder mehreren Ablagestationen (50) verbunden zu werden.
- Die Anlage gemäß Anspruch 1, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") zwischen mindestens zwei Stellungen in Bezug auf die feste Struktur (21) bewegbar ist, um die Abgabeachse (22) der Sprühauftragsvorrichtung mit einer Translations- und/oder Rotationsbewegung zu variieren, während die Abgabeachse (22) in einer einzigen Ebene gehalten wird.
- Anlage gemäß Anspruch 1, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") zwischen mindestens zwei stabilen Stellungen um eine Achse drehbar ist, die mit ihrer eigenen Abgabeachse (22) zusammenfällt.
- Die Anlage gemäß Anspruch 1, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") ein Rotationszerstäuber ist.
- Die Anlage gemäß Anspruch 1, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") ein elektrostatischer Zerstäuber ist.
- Ein Lackierverfahren umfassend die Schritte:a) Bereitstellen mindestens eines Trägerrahmens (30) für die zu lackierenden Teile, einer oder mehrerer auf einer festen Struktur (21) installierten Sprühlack-Auftragsvorrichtungen (20, 20', 20") und eines sechsachsigen anthropomorphen Roboters (10) mit am Ende davon montierten lösbaren Eingriffsmitteln (13, 14), um den mindestens einen Trägerrahmen (30) in Bezug auf die Sprühauftragsvorrichtungen (20, 20', 20") zu bewegen;b) Bewegen des mindestens einen Trägerrahmens (30) durch einen anthropomorphen Roboter (10) in Bezug auf die Sprühauftragsvorrichtungen (20, 20', 20") während des Lackierens, wobei der anthropomorphe Roboter (10) an seinem Ende lösbare Eingriffsmittel (13, 14) aufweist, um den mindestens einen Trägerrahmen (30) zu tragen,
gekennzeichnet durch Bereitstellen eines Abzugs mit Hilfe von Absaugöffnungen (46) zum Absaugen des den Sprühauftragsvorrichtungen (20, 20', 20") zugewandten Luftstroms, wobei die Basis (11) des anthropomorphen Roboters (10) den Sprühauftragsvorrichtungen (20, 20', 20") in Bezug auf die Richtung und den Weg des durch Absaugen angesaugten Luftstroms vorgeschaltet ist, und dass die Basis (11) des anthropomorphen Roboters (10) in Bezug auf die Richtung und den Weg der Farbabgabe durch die Sprühauftragsvorrichtungen (20, 20', 20") stromaufwärts der Sprühauftragsvorrichtungen (20, 20', 20") angeordnet ist. - Das Verfahren gemäß Anspruch 10, wobei eine Abschirmung (17) senkrecht zur Drehachse des Handgelenks des anthropomorphen Roboters (10) vorgesehen ist, um die Gelenkverbindung des anthropomorphen Roboters (10) zu schützen.
- Das Verfahren gemäß Anspruch 10, wobei die lösbaren Eingriffsmittel (13, 14) einen Stift (13) umfassen, der in einen hohlen Pfosten (33) des mindestens einen Trägerrahmens (30) eingepasst werden kann, dadurch gekennzeichnet, dass der Stift (13) und der Pfosten (33) mit den jeweiligen Achsen ausgerichtet ist und koplanar zur Drehachse des Handgelenks des anthropomorphen Roboters (10) gehalten wird, wenn der mindestens eine Trägerrahmen (30) mit dem anthropomorphen Roboter (10) verbunden ist und die Sprühlackabgabe aktiviert wird.
- Das Verfahren gemäß Anspruch 10, gekennzeichnet durch Ablegen des mindestens einen Trägerrahmens (30) auf Hakenmittel (55) von mindestens einer Ablagestation (50), wenn er von dem anthropomorphen Roboter (10) freigegeben wird, und/oder durch Aufnehmen des mindestens einen Trägerrahmens (30) von der Ablagestation (50) durch den anthropomorphen Roboter (10).
- Das Verfahren gemäß Anspruch 10, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") zwischen mindestens zwei Stellungen in Bezug auf die feste Struktur (21) bewegt wird, um die Abgabeachse (22) der Sprühauftragsvorrichtung (20, 20', 20") mit einer Translations- und/oder Rotationsbewegung zu variieren, wobei die Achse (22) in einer einzigen Ebene beibehalten wird.
- Das Verfahren gemäß Anspruch 10, wobei mindestens eine der Sprühauftragsvorrichtungen (20, 20', 20") zwischen mindestens zwei stabilen Stellungen um eine Achse gedreht wird, die mit ihrer eigenen Abgabeachse (22) zusammenfällt.
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| ITUB2016A000922A ITUB20160922A1 (it) | 2016-02-22 | 2016-02-22 | Impianto e metodo di verniciatura. |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP3207998A1 EP3207998A1 (de) | 2017-08-23 |
| EP3207998B1 true EP3207998B1 (de) | 2020-04-15 |
Family
ID=55969400
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP17157046.8A Active EP3207998B1 (de) | 2016-02-22 | 2017-02-21 | Lackierung anlage und anwendungsverfahren |
Country Status (2)
| Country | Link |
|---|---|
| EP (1) | EP3207998B1 (de) |
| IT (1) | ITUB20160922A1 (de) |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP6664768B1 (ja) * | 2019-03-12 | 2020-03-13 | カワノ株式会社 | 接着剤塗布装置及び接着剤塗布方法 |
| CN111014760B (zh) * | 2019-12-14 | 2020-12-18 | 河南飞龙(芜湖)汽车零部件有限公司 | 一种应用于汽车水泵生产线上的钻孔喷涂一体化装置 |
| CN111036454A (zh) * | 2020-01-21 | 2020-04-21 | 程庆 | 适用于具有凸条结构的板材的喷漆设备 |
Family Cites Families (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP4526170B2 (ja) * | 2000-08-31 | 2010-08-18 | 本田技研工業株式会社 | 塗装設備 |
| DE102005033972A1 (de) * | 2005-07-20 | 2007-01-25 | Dürr Systems GmbH | Beschichtungsverfahren und zugehörige Beschichtungseinrichtung |
| FR2954716B1 (fr) | 2009-12-29 | 2012-02-10 | Plastic Omnium Cie | Procede de traitement surfacique de pieces de grandes dimensions, prehenseur de pieces adapte pour la mise en oeuvre d'un tel procede, utilisation de ce prehenseur et cabine de traitement |
| FR2961718B1 (fr) | 2010-06-29 | 2012-08-17 | Plastic Omnium Cie | Procede et cabine de peinture d'une piece de carrosserie de vehicule automobile |
| JP2015100761A (ja) * | 2013-11-26 | 2015-06-04 | 曙ブレーキ工業株式会社 | 支持具、粉体塗布システム、粉体塗布方法、及びキャリパ |
-
2016
- 2016-02-22 IT ITUB2016A000922A patent/ITUB20160922A1/it unknown
-
2017
- 2017-02-21 EP EP17157046.8A patent/EP3207998B1/de active Active
Non-Patent Citations (1)
| Title |
|---|
| None * |
Also Published As
| Publication number | Publication date |
|---|---|
| ITUB20160922A1 (it) | 2017-08-22 |
| EP3207998A1 (de) | 2017-08-23 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN111032232B (zh) | 用于用涂料粉末涂覆工件的粉末涂覆设备 | |
| JP7449239B2 (ja) | コンパクトな塗装ブースのためのロボット装置 | |
| US8726830B2 (en) | Robot comprising a cleaning device and associated operating method | |
| US9004846B2 (en) | Gripper assembly for moving device | |
| RU2442665C2 (ru) | Установка для нанесения лакокрасочного покрытия и способ ее эксплуатации | |
| US8397662B2 (en) | Coating method and associated coating device | |
| KR101518105B1 (ko) | 반송 장치 및 로봇 시스템 | |
| EP3207998A1 (de) | Lackierungsanlage und anwendungsverfahren | |
| US20130026676A1 (en) | Method for the surface treatment of large parts, gripper of parts suitable for implementing such a method, use of said gripper and treatment cubicle | |
| US20070169691A1 (en) | Automatic retouching device for a powder-coating booth | |
| US20140245953A1 (en) | System for coating, in particular for painting, articles, in particular vehicle bodies | |
| CN107835728A (zh) | 涂覆设备机器人、特别是操纵机器人 | |
| US20120205928A1 (en) | Gripper Assembly for Mechanical Device | |
| CN105562383A (zh) | 用于涂覆系统的一个或多个部件的清洁方法和清洁装置 | |
| EP3087835B1 (de) | Verfahren zur pestizidbehandlung von landwirtschaftlichem erntegut | |
| EP4066947A1 (de) | Reinigungsstation zum reinigen der spritzpistolen in einer spritzkabine und verfahren | |
| EP3184179B1 (de) | Anlage zur horizontalen lackierung von geformten türen | |
| US9573153B2 (en) | Coating installation and corresponding operating method | |
| IT201900009714A1 (it) | Apparato per la applicazione di vernici su manufatti a prevalente estensione piana | |
| JP7855343B2 (ja) | 静電粉末コーティングのためのロボット、システム及び方法 | |
| WO2022167961A1 (en) | Coating method and automated coating devices with multiple-nozzle heads | |
| ITBG20100068A1 (it) | Cabina di verniciatura per impianti di verniciatura di manufatti. | |
| EP1909969A1 (de) | Spritzkabine für anlagen zum anstreichen/lackieren von produkten | |
| JP6755103B2 (ja) | 塗装ブース及びそれを用いた塗装方法 | |
| JP2018103117A (ja) | 塗装ブース |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| AX | Request for extension of the european patent |
Extension state: BA ME |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20180223 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20191126 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602017014622 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: REF Ref document number: 1256634 Country of ref document: AT Kind code of ref document: T Effective date: 20200515 |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20200415 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG4D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200716 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200715 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200815 Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200817 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MK05 Ref document number: 1256634 Country of ref document: AT Kind code of ref document: T Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200715 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602017014622 Country of ref document: DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: IT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| 26N | No opposition filed |
Effective date: 20210118 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20210221 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20210228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210228 Ref country code: LI Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210228 Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210221 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210228 Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210221 Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210221 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20170221 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20200415 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20260217 Year of fee payment: 10 |