EP1081082B1 - Traverse device - Google Patents
Traverse device Download PDFInfo
- Publication number
- EP1081082B1 EP1081082B1 EP20000118313 EP00118313A EP1081082B1 EP 1081082 B1 EP1081082 B1 EP 1081082B1 EP 20000118313 EP20000118313 EP 20000118313 EP 00118313 A EP00118313 A EP 00118313A EP 1081082 B1 EP1081082 B1 EP 1081082B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- traverse
- oscillating arm
- traverse device
- oscillating
- yarn
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Lifetime
Links
- 230000010355 oscillation Effects 0.000 claims description 16
- 238000001514 detection method Methods 0.000 claims description 13
- 238000004804 winding Methods 0.000 claims description 8
- 230000001133 acceleration Effects 0.000 description 2
- 230000015572 biosynthetic process Effects 0.000 description 2
- 230000033001 locomotion Effects 0.000 description 2
- 241001589086 Bellapiscis medius Species 0.000 description 1
- 230000003190 augmentative effect Effects 0.000 description 1
- 230000005540 biological transmission Effects 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 230000003292 diminished effect Effects 0.000 description 1
- 230000000694 effects Effects 0.000 description 1
- 230000003993 interaction Effects 0.000 description 1
Images



Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/28—Traversing devices; Package-shaping arrangements
- B65H54/2827—Traversing devices with a pivotally mounted guide arm
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/28—Traversing devices; Package-shaping arrangements
- B65H54/2833—Traversing devices driven by electromagnetic means
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/28—Traversing devices; Package-shaping arrangements
- B65H54/2881—Traversing devices with a plurality of guides for winding on a plurality of bobbins
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/30—Handled filamentary material
- B65H2701/31—Textiles threads or artificial strands of filaments
Definitions
- the present invention relates to a traverse device unit according to the preamble of claim 1 for traversing a yarn that is wound into a package.
- a known traverse device unit of this kind traverses a yarn while transferring it between an upper and lower set of wings that rotate in opposite directions.
- This wing traverse device unit does not easily accommodate a mechanism for changing a position where traversing is turned, that is, a position where a yarn is transferred between the sets of wings, so that it is difficult to arbitrarily change a right and left traverse turn position, that is, a traverse range in order to form packages in an arbitrary form.
- a yarn guide for threading a yarn may be connected to a linear motor so as to be reciprocated to arbitrarily change the right and left traverse turn positions.
- the linear motor requires a motor stroke corresponding to the traverse range, resulting in an increase in the size of the entire device including the linear motor.
- Document US-A-5 523 911 discloses a traverse device unit for a magnetic disk drive including an oscillating arm member pivotably supported by a shaft.
- the arm member is driven by an electrical coil motor comprising a moveable member and a stator.
- the stator is formed by one or more stationary permanent magnets while the oscillating arm member is formed by a coil mounted on one end of the oscillating arm member and surrounding the permanent magnet.
- the permanent magnets each have N and S poles arranged on a surface thereof.
- a yarn traverse device comprising the features of claim 1 wherein the features set forth in the preamble are known from US-A-5 523 911.
- the traverse device unit comprises an oscillating arm member having a yarn guide, a voice coil motor connected to the oscillating arm member and driven normally and reversely within a predetermined range, and control means for controlling the normal and reverse driving of the voice coil motor, the control means determining a range within which the oscillating arm member is oscillated.
- a yarn traverse range is determined by the oscillating range of the oscillating arm member, which is in turn determined by the control means for controlling the motor.
- a traverse width can be gradually narrowed, that is, a position where traversing is turned can be gradually moved inward to easily wind a yarn into a tapered-end package or the traverse width can be periodically or non-periodically narrowed, that is, the traverse turn position can be periodically or non-periodically moved inward to carry out creeping to prevent saddle bag shapes.
- Normal and reverse driving of the voice coil motor within a predetermined range is controlled by a command value such as a triangular wave in such a manner that the normal and reverse driving operations are switched at peaks or bottoms of the command value, thereby enabling high-speed braking and acceleration before and after the oscillating arm member is turned.
- high-speed turns are achieved by directly attaching an elongated light oscillating arm member to a shaft of the voice coil motor while attaching a small light yarn guide to a tip of the oscillating arm member.
- the present invention is a traverse device unit comprising an oscillating arm member having a yarn guide, a motor connected to the oscillating arm member and driven normally and reversely within a predetermined range, and control means for controlling the normal and reverse driving of the motor, a plurality of the oscillating arm members being arranged in a traverse direction so as to transfer a yarn between the adjacent oscillating arm members.
- the traverse range is divided into two or more so that oscillating ranges of the two or more short oscillating arm members can be combined together to obtain a wide traverse range.
- the short oscillating arm members serve to reduce the inertia while increasing the turn speed.
- the present invention is a traverse device unit that individually controls oscillation of the plurality of oscillating arm members.
- the present invention is a traverse device unit comprising detection means for detecting a normal and reverse driving range of the motor over the entire range.
- the detection means can be used for feedback control to accurately control the traverse turn positions. Additionally, if the yarn is transferred between the plurality of oscillating arm members, yarn transfer positions can be accurately controlled by, for example, controlling oscillation of a receiving-side oscillating arm member depending on the position of a delivering-side oscillating position.
- a traverse device unit 1 comprises an oscillating arm member 11, a voice coil motor 12, a control section 13, and a detection section 14.
- the traverse device unit 1 has no mechanical part such as a damper which determines a position where oscillation of the arm member 11 is inverted, and a traverse range L is determined by oscillation of the arm member 11 connected to the voice coil motor 12.
- a yarn Y traversed by the traverse device unit 1 is wound into a package 3 that is in contact with a rotatively driven friction drum 2.
- a yarn guide 21 for guiding the yarn Y is attached to a tip of the oscillating arm member 11.
- the oscillating arm member 11 has the other side or its intermediate portion connected to a shaft 22 so as to oscillate around the shaft 22.
- the oscillating arm member 11 has the voice coil motor 12 connected to the other end thereof.
- the oscillating arm member 11 constitutes an oscillating member having the yarn guide and connected to the voice coil motor 12 so as to be normally and reversely driven within a predetermined range.
- the voice coil motor (oscillating motor) 12 provided at the other end of the oscillating arm member 11 and driven normally and reversely within a predetermined range comprises a stator 23 comprising a permanent magnet shaped like a fan extended around the shaft 22 and a movable member 24 provided to surround the stator 23 and comprising a fan-shaped air-core coil.
- the relationship between the stator 23 and the movable member 24 is similar to that between a magnet and a coil, and the movable member 24 is oscillated around the shaft 22 by means of a driving force exerted based on interactions between a current flowing through the coil and magnetic fields crossing the current.
- a permanent magnet surface of the stator 23 which is opposed to the movable member 24 has N or S poles contiguously disposed in a driving direction, compared to the other linear motors having N and S poles alternately disposed in the driving direction. Accordingly, when the movable member 24 is driven in one direction, the direction of a current flowing through a coil in the movable member 24 need not be switched.
- the movable member 24, which is driven normally and reversely within a range within which the stator 23 is present, is supplied with power via flexible power-supplying line.
- the stator 23 may be a coil, while the movable member 24 may be a permanent magnet.
- the normal and reverse driving range of the movable member 24 is determined by a voltage supplied to the coil. Consequently, to change turn positions at traverse ends, a peak height (amplitude) of a triangular wave voltage supplied to the coil can be changed.
- the power supplied to the coil is not limited to the triangular wave voltage.
- the movable member 24 When the movable member 24 is constructed using the air core coil, its weight can be reduced to allow the oscillating arm member 11 to be inverted at a high speed.
- the stator 23 is shaped like a fan covering the normal and reverse driving range of the movable member 24 and the movable member 24 may be sized to move along the stator 23, the weight of the movable member 24 and thus its inertia can be reduced, compared to motors that rotate through 360 degrees. As a result, the oscillating arm member 11 can be inverted at a high speed when its direction is changed.
- the control section 13 has a servo function and outputs a command signal to the voice coil motor 12 to control oscillations effected by the voice coil motor 12.
- the control section 13 is provided for each voice coil motor 12.
- the detection section 14 detection means
- the control section 13 uses feedback control based on an output from the detection section 14 to arbitrarily control a position where and a time when an oscillation is effected by the voice coil motor 12.
- Figure 2 shows a specific example of the control section 13 including an analogical servo function.
- the detection section 14 comprises a magneto-resistance element that varies a resistance value depending on the position of the movable member 24.
- a voltage corresponding to a difference between an output voltage value from the magneto-resistance element (detection section 14) and a command voltage value is output to the voice coil motor 12 through a comparator 26 and supplied to the coil (movable member 24) of the voice coil motor 12, which effects predetermined normal and reverse driving in a manner following the command value. That is, a current corresponding to the difference between the output voltage value from the detection section 14 and the command voltage value flows through the coil of the voice coil motor 12.
- control section 13 may include a digital servo function.
- the present invention is not limited to the feedback control, but open control can be employed where a spring is provided for the oscillating shaft so that its position is controlled while maintaining the balance with an urging force of the spring.
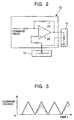
- Figure 3 is a graph showing an example of a command value output from the control section 13 in Figure 2.
- the command value is output as a triangular wave voltage.
- the height of the triangular wave determines the normal and reverse driving range of the voice coil motor 12, and the period of the triangular wave determines a speed at which the voice coil motor 12 is driven normally and reversely. This enables controlling of oscillating motions of the arm 11 connected to the voice coil motor 12.
- a current value is particularly high near a peak of the command value (near a position where the oscillating arm member 11 is turned). This large variation in current induces braking before a turn as well as acceleration after a turn to enable the oscillating arm member 11 to be inverted at a high speed without using an energy accumulating device against which the arm oscillating arm member 11 collides.
- the control section 13 outputs a triangular wave of a predetermined height and a predetermined period to normally and reversely drive the voice coil motor 12 to traverse the yarn Y within the predetermined traverse range L, the yarn Y being guided by the yarn guide 21 disposed at the tip of the oscillating arm member 11.
- the control section 13 provides such control that the triangular wave in Figure 3 has its height gradually reduced depending on the elapsed time or a measured yarn length. Accordingly, the traverse range L narrows gradually to allow a tapered-end package as shown in Figure 1 to be formed easily.
- a creeping operation of periodically or non-periodically mixing a lower triangular wave as shown by the alternate long and two short dashes line in Figure 3 can be performed to prevent saddle bag shapes from being formed at turn sections corresponding to opposite ends of the traverse range, thereby obtaining a package having a yarn layer with a straight surface.
- the voice coil motor 12 is structured to normally and reversely drive the oscillating arm member 11 in a fashion tracing a fan around the shaft 22, the normal and reverse driving range is limited to enable the size and inertia of the motor to be reduced.
- the weights of the oscillating arm member 11 and the yarn guide 21 disposed at the tip thereof are minimized to enable the oscillating arm member 11 to be turned at a high speed.
- the above described traverse device unit with the single oscillating arm member 11 is preferably applicable to a double twister or the like.
- the single oscillating arm member type is also applicable to a spun yarn winder with a narrow traverse range.
- Figure 4 is a schematic structural drawing of another traverse device according to the present invention.
- four oscillating arm members are arranged in juxtaposition in a traverse direction (an axial direction of a winding package) to accommodate high-speed traversing.
- Description of that part of the configuration of this traverse device which is common to the traverse device unit (single arm type) is omitted as appropriate.
- the traverse device 30 comprises traverse device units 31 and 32 for turning the yarn rightward or leftward traverse device and central traverse device units 33 and 34 for transferring the yarn.
- Each of the traverse device units 31 to 34 has an oscillating arm member 35, a voice coil motor (an oscillating motor) 36, a control section 37, and a detection section 38.
- a main control section 39 controls the control sections 37, and each control section 37 controls a position where the oscillating arm member 35 is oscillated, based on a command from the main control section 39.
- the control sections 37 and the main control section 39 constitute control means.
- the traverse device may comprise two or more traverse device units, for example, only the right and left traverse device units and one central traverse device unit.
- the yarn is transferred from the right to left traverse device units or from the left to right traverse device units at a point P1 between the traverse device units 31 and 33, a point P2 between the traverse device units 33 and 34, and a point P3 between the traverse device units 34 and 32.
- the oscillating arm member 35 transfers the yarn during oscillation at the yarn transfer points P1, P2, and P3. That is, the delivering-side arm 35 stops the oscillation after transferring the yarn, and the receiving-side arm receives the yarn after starting oscillation.
- the yarn is transferred from the oscillating arm member 35 to the subsequent oscillating arm member 35, thereby allowing the yarn to be transferred at the points P1, P2, and P3 at a high speed.
- Appropriate guide plates are provided at the yarn transfer points P1, P2, and P3 to transfer the yarn from one yarn guide to another, but illustration thereof is omitted.
- the guide plates are each shaped to instantly receive the yarn from the delivering-side yarn guide and to transfer it to the receiving-side yarn guide.
- the present invention is not limited to the oscillating arm member 35 that transfers the yarn during oscillation, but the delivering side arm may stop at the transfer position, while the receiving-side arm may start oscillation at this transfer position, so that the yarn is transported over the total oscillating range of the plurality of arms.
- Figure 5 is a graph showing timings in a command voltage generated by each control section 37 due to a command from the main control section 39 in Figure 4.
- each oscillating arm member 35 lies leftward.
- the oscillating arm member 35 of the left traverse device unit 31 oscillates rightward from a turn position T1 and transfers, at the point P2, the yarn to the oscillating arm member 35 of the central traverse device unit 34.
- the oscillating arm member 35 of the central traverse device unit 34 oscillates rightward and transfers, at the point P3, the yarn to the oscillating arm member 35 of the right traverse device unit 32.
- the oscillating arm member 35 of the right traverse device unit 32 moves to a turn position T2. Subsequently, in response to a voltage drop in each traverse device unit, the yarn is transferred from the turn position T2 to the turn position T1. Repeating the above operation allows the yarn Y to be traversed within the traverse range.
- the oscillation range of the oscillating arm member 35 of each of the traverse device units 31 to 34 is narrowed to correspondingly enable the oscillating arm member 35 to be shortened.
- inertia exerted during oscillation is diminished to enable the size of the entire traverse device to be reduced to accommodate high-speed turns.
- the length of the oscillating arm member 35 of each of the right and left traverse device units 31 and 32 (this length equals the distance from the oscillating shaft to the yarn guide) can also be reduced below that of each of the central traverse device units 33 and 34 to accommodate high-speed turns.
- a pattern of an increase or decrease in voltage at each of the traverse device units 31 to 34 can be individually varied to shift the yarn transfer points P1, P2, and P3 in the traverse direction (the axial direction of the package) to hinder straight winding at these points P1, P2, and P3.
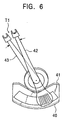
- FIG. 6 is a partial structural drawing of yet another traverse device.
- Two traverse device units 40 and 41 are stacked on each other (in the direction of the oscillating shaft) in a right and left portions where traversing is turned, so that the yarn is transferred between an upper oscillating arm member 42 and a lower oscillating arm member 43, which are overlapping each other.
- a guide plate (not shown in the drawing) can be provided as appropriate to reliably transfer the yarn from the upper oscillating arm member 42 to the lower oscillating arm member 43.
- the yarn traverse range is determined by the oscillating range of the oscillating member, which is in turn determined by the control means for controlling the voice coil motor.
- the traverse range can be gradually narrowed to easily wind the yarn into a tapered-end package or the traverse range can be periodically or non-periodically varied to carry out creeping to prevent saddle bag shapes.
- the present invention eliminates the needs for drive transmission means such as an endless belt to thereby improve durability while enabling the size of the entire traverse device to be reduced.
- the voice coil motor that is subjected to a small inertia and that can be switched between normal and reverse driving at a high speed serves to achieve high-speed turns to enable accurate formation of packages in a predetermined form such as a tapered end while preventing saddle bag shapes.
- the traverse range is divided into two or more so that the oscillating ranges of the two or more short oscillating arm members can be combined together to obtain a wide traverse range.
- the short oscillating arm members serve to reduce the inertia while increasing the turn speed, thereby enabling packages in an accurate form to be obtained while preventing saddle bag shapes.
- the number of oscillating arm members can be augmented to accommodate a wide traverse range.
- the detection means can be used for feedback control to accurately control the traverse turn positions. Additionally, if the yarn is transferred between the plurality of oscillating arm members, the yarn transfer positions can be accurately controlled. As a result, packages obtained have an appropriate winding form, and the yarn can be reliably transferred to prevent winding errors.
Landscapes
- Physics & Mathematics (AREA)
- Electromagnetism (AREA)
- Winding Filamentary Materials (AREA)
- Spinning Or Twisting Of Yarns (AREA)
Description
- The present invention relates to a traverse device unit according to the preamble of
claim 1 for traversing a yarn that is wound into a package. - A known traverse device unit of this kind traverses a yarn while transferring it between an upper and lower set of wings that rotate in opposite directions.
- This wing traverse device unit does not easily accommodate a mechanism for changing a position where traversing is turned, that is, a position where a yarn is transferred between the sets of wings, so that it is difficult to arbitrarily change a right and left traverse turn position, that is, a traverse range in order to form packages in an arbitrary form.
- It is contemplated that a yarn guide for threading a yarn may be connected to a linear motor so as to be reciprocated to arbitrarily change the right and left traverse turn positions. In this case, however, the linear motor requires a motor stroke corresponding to the traverse range, resulting in an increase in the size of the entire device including the linear motor.
- Document WO 00/37346 (Prior art under Article 54(3) EPC) discloses a yarn traverse device unit having an arm member pivotably supported by a shaft. The arm member is driven by an electrical coil motor which is formed by two stationary magnets defining an air gap therebetween and an electric coil extending through the air gap. In particular, each of the two magnets has N and S poles on a surface thereof.
- Document WO 00/24663 (Prior art under Article 54(3) EPC) describes a traverse device unit having an oscillating arm member which is pivotably supported by a shaft. The arm member is driven by an electrical coil motor. The coil motor is formed by an electrical coil mounted on a top surface of the arm member and two fixed permanent magnets. The permanent magnets are arranged at positions defining the oscillating range end positions. In operation, the electrical coil together with the arm member is oscillated between the fixed permanent magnets due to electromagnetic forces.
- Document US-A-5 523 911 discloses a traverse device unit for a magnetic disk drive including an oscillating arm member pivotably supported by a shaft. The arm member is driven by an electrical coil motor comprising a moveable member and a stator. The stator is formed by one or more stationary permanent magnets while the oscillating arm member is formed by a coil mounted on one end of the oscillating arm member and surrounding the permanent magnet. The permanent magnets each have N and S poles arranged on a surface thereof.
- It is an object of the present invention to provide a traverse device unit of the above mentioned kind which is less complicated in structure, however, which has an improved efficiency and is capable for high speed reverse movement of a traversing arm member.
- In accordance with the present invention there is provided a yarn traverse device comprising the features of
claim 1 wherein the features set forth in the preamble are known from US-A-5 523 911. - The traverse device unit comprises an oscillating arm member having a yarn guide, a voice coil motor connected to the oscillating arm member and driven normally and reversely within a predetermined range, and control means for controlling the normal and reverse driving of the voice coil motor, the control means determining a range within which the oscillating arm member is oscillated.
- With this configuration, a yarn traverse range is determined by the oscillating range of the oscillating arm member, which is in turn determined by the control means for controlling the motor. Thus, by changing the oscillating range of the oscillating arm member, a traverse width can be gradually narrowed, that is, a position where traversing is turned can be gradually moved inward to easily wind a yarn into a tapered-end package or the traverse width can be periodically or non-periodically narrowed, that is, the traverse turn position can be periodically or non-periodically moved inward to carry out creeping to prevent saddle bag shapes.
- Normal and reverse driving of the voice coil motor within a predetermined range is controlled by a command value such as a triangular wave in such a manner that the normal and reverse driving operations are switched at peaks or bottoms of the command value, thereby enabling high-speed braking and acceleration before and after the oscillating arm member is turned. In addition, high-speed turns are achieved by directly attaching an elongated light oscillating arm member to a shaft of the voice coil motor while attaching a small light yarn guide to a tip of the oscillating arm member.
- Alternatively, the present invention is a traverse device unit comprising an oscillating arm member having a yarn guide, a motor connected to the oscillating arm member and driven normally and reversely within a predetermined range, and control means for controlling the normal and reverse driving of the motor, a plurality of the oscillating arm members being arranged in a traverse direction so as to transfer a yarn between the adjacent oscillating arm members.
- With this configuration, the traverse range is divided into two or more so that oscillating ranges of the two or more short oscillating arm members can be combined together to obtain a wide traverse range. The short oscillating arm members serve to reduce the inertia while increasing the turn speed.
- Alternatively, the present invention is a traverse device unit that individually controls oscillation of the plurality of oscillating arm members.
- With this configuration, by changing driving timings and/or driving ranges for the plurality of oscillating arm members, positions where the yarn is transferred between the oscillating arm members can be shifted to suppress straight winding at these transfer positions.
- Alternatively, the present invention is a traverse device unit comprising detection means for detecting a normal and reverse driving range of the motor over the entire range.
- With this configuration, the detection means can be used for feedback control to accurately control the traverse turn positions. Additionally, if the yarn is transferred between the plurality of oscillating arm members, yarn transfer positions can be accurately controlled by, for example, controlling oscillation of a receiving-side oscillating arm member depending on the position of a delivering-side oscillating position.
-
- Figure 1 is a schematic structural drawing of a traverse device unit according to the present invention.
- Figure 2 is a block diagram of a control section.
- Figure 3 is graph showing how a command voltage is output from the control section.
- Figure 4 is a schematic structural drawing of a traverse device showing another example of the present invention.
- Figure 5 is a graph showing how a command voltage is output from a control section for each arm.
- Figure 6 is a partial structural drawing of a traverse device unit showing yet another example of the present invention.
- Embodiments of the present invention will be described with reference to the drawings.
- In Figure 1, a
traverse device unit 1 comprises an oscillatingarm member 11, avoice coil motor 12, acontrol section 13, and adetection section 14. Thetraverse device unit 1 has no mechanical part such as a damper which determines a position where oscillation of thearm member 11 is inverted, and a traverse range L is determined by oscillation of thearm member 11 connected to thevoice coil motor 12. A yarn Y traversed by thetraverse device unit 1 is wound into apackage 3 that is in contact with a rotatively drivenfriction drum 2. - A
yarn guide 21 for guiding the yarn Y is attached to a tip of the oscillatingarm member 11. The oscillatingarm member 11 has the other side or its intermediate portion connected to ashaft 22 so as to oscillate around theshaft 22. The oscillatingarm member 11 has thevoice coil motor 12 connected to the other end thereof. The oscillatingarm member 11 constitutes an oscillating member having the yarn guide and connected to thevoice coil motor 12 so as to be normally and reversely driven within a predetermined range. - The voice coil motor (oscillating motor) 12 provided at the other end of the oscillating
arm member 11 and driven normally and reversely within a predetermined range comprises a stator 23 comprising a permanent magnet shaped like a fan extended around theshaft 22 and amovable member 24 provided to surround the stator 23 and comprising a fan-shaped air-core coil. The relationship between the stator 23 and themovable member 24 is similar to that between a magnet and a coil, and themovable member 24 is oscillated around theshaft 22 by means of a driving force exerted based on interactions between a current flowing through the coil and magnetic fields crossing the current. In thisvoice coil motor 12, a permanent magnet surface of the stator 23 which is opposed to themovable member 24 has N or S poles contiguously disposed in a driving direction, compared to the other linear motors having N and S poles alternately disposed in the driving direction. Accordingly, when themovable member 24 is driven in one direction, the direction of a current flowing through a coil in themovable member 24 need not be switched. Themovable member 24, which is driven normally and reversely within a range within which the stator 23 is present, is supplied with power via flexible power-supplying line. The stator 23 may be a coil, while themovable member 24 may be a permanent magnet. - The normal and reverse driving range of the
movable member 24 is determined by a voltage supplied to the coil. Consequently, to change turn positions at traverse ends, a peak height (amplitude) of a triangular wave voltage supplied to the coil can be changed. The power supplied to the coil is not limited to the triangular wave voltage. - When the
movable member 24 is constructed using the air core coil, its weight can be reduced to allow the oscillatingarm member 11 to be inverted at a high speed. In addition, since the stator 23 is shaped like a fan covering the normal and reverse driving range of themovable member 24 and themovable member 24 may be sized to move along the stator 23, the weight of themovable member 24 and thus its inertia can be reduced, compared to motors that rotate through 360 degrees. As a result, the oscillatingarm member 11 can be inverted at a high speed when its direction is changed. - The control section 13 (control means) has a servo function and outputs a command signal to the
voice coil motor 12 to control oscillations effected by thevoice coil motor 12. Thecontrol section 13 is provided for eachvoice coil motor 12. Preferably, the detection section 14 (detection means) is, for example, a rotary encoder that can detect the oscillation of theshaft 22 over the entire range. Thecontrol section 13 uses feedback control based on an output from thedetection section 14 to arbitrarily control a position where and a time when an oscillation is effected by thevoice coil motor 12. - Figure 2 shows a specific example of the
control section 13 including an analogical servo function. In this example, thedetection section 14 comprises a magneto-resistance element that varies a resistance value depending on the position of themovable member 24. In the feedback circuit shown in Figure 2, a voltage corresponding to a difference between an output voltage value from the magneto-resistance element (detection section 14) and a command voltage value is output to thevoice coil motor 12 through acomparator 26 and supplied to the coil (movable member 24) of thevoice coil motor 12, which effects predetermined normal and reverse driving in a manner following the command value. That is, a current corresponding to the difference between the output voltage value from thedetection section 14 and the command voltage value flows through the coil of thevoice coil motor 12. When the output voltage value from thedetection section 14 equals the command voltage value, an output from thecomparator 26 becomes zero to cause no current to flow through thevoice coil motor 12. Another example of thecontrol section 13 may include a digital servo function. In addition, the present invention is not limited to the feedback control, but open control can be employed where a spring is provided for the oscillating shaft so that its position is controlled while maintaining the balance with an urging force of the spring. - Figure 3 is a graph showing an example of a command value output from the
control section 13 in Figure 2. The command value is output as a triangular wave voltage. The height of the triangular wave determines the normal and reverse driving range of thevoice coil motor 12, and the period of the triangular wave determines a speed at which thevoice coil motor 12 is driven normally and reversely. This enables controlling of oscillating motions of thearm 11 connected to thevoice coil motor 12. A current value is particularly high near a peak of the command value (near a position where theoscillating arm member 11 is turned). This large variation in current induces braking before a turn as well as acceleration after a turn to enable theoscillating arm member 11 to be inverted at a high speed without using an energy accumulating device against which the arm oscillatingarm member 11 collides. - Next, the operation of the traverse device unit configured as described above will be explained with reference to Figure 1. In the illustrated example, a tapered-end package is formed.
- The
control section 13 outputs a triangular wave of a predetermined height and a predetermined period to normally and reversely drive thevoice coil motor 12 to traverse the yarn Y within the predetermined traverse range L, the yarn Y being guided by theyarn guide 21 disposed at the tip of theoscillating arm member 11. Thecontrol section 13 provides such control that the triangular wave in Figure 3 has its height gradually reduced depending on the elapsed time or a measured yarn length. Accordingly, the traverse range L narrows gradually to allow a tapered-end package as shown in Figure 1 to be formed easily. In addition, a creeping operation of periodically or non-periodically mixing a lower triangular wave as shown by the alternate long and two short dashes line in Figure 3 can be performed to prevent saddle bag shapes from being formed at turn sections corresponding to opposite ends of the traverse range, thereby obtaining a package having a yarn layer with a straight surface. - Since the
voice coil motor 12 is structured to normally and reversely drive theoscillating arm member 11 in a fashion tracing a fan around theshaft 22, the normal and reverse driving range is limited to enable the size and inertia of the motor to be reduced. - In addition, no mechanical part such as a damper is provided at the turn portions of the oscillating range, so that the oscillating range, that is, traverse range of the
oscillating arm member 11 can be arbitrarily set to easily form tapered-end packages while performing a creeping operation to prevent formation of saddle bag shapes. - In addition, the weights of the
oscillating arm member 11 and theyarn guide 21 disposed at the tip thereof are minimized to enable theoscillating arm member 11 to be turned at a high speed. - Since, however, a longer
oscillating arm member 11 limits high-speed turns, the above described traverse device unit with the singleoscillating arm member 11 is preferably applicable to a double twister or the like. The single oscillating arm member type is also applicable to a spun yarn winder with a narrow traverse range. - Figure 4 is a schematic structural drawing of another traverse device according to the present invention. For example, four oscillating arm members are arranged in juxtaposition in a traverse direction (an axial direction of a winding package) to accommodate high-speed traversing. Description of that part of the configuration of this traverse device which is common to the traverse device unit (single arm type) is omitted as appropriate.
- The
traverse device 30 comprisestraverse device units traverse device units traverse device units 31 to 34 has anoscillating arm member 35, a voice coil motor (an oscillating motor) 36, acontrol section 37, and adetection section 38. In addition, amain control section 39 controls thecontrol sections 37, and eachcontrol section 37 controls a position where theoscillating arm member 35 is oscillated, based on a command from themain control section 39. Thecontrol sections 37 and themain control section 39 constitute control means. The traverse device may comprise two or more traverse device units, for example, only the right and left traverse device units and one central traverse device unit. - Since there are four traverse device units in Figure 4, the yarn is transferred from the right to left traverse device units or from the left to right traverse device units at a point P1 between the
traverse device units traverse device units traverse device units oscillating arm member 35 transfers the yarn during oscillation at the yarn transfer points P1, P2, and P3. That is, the delivering-side arm 35 stops the oscillation after transferring the yarn, and the receiving-side arm receives the yarn after starting oscillation. As a result, the yarn is transferred from theoscillating arm member 35 to the subsequentoscillating arm member 35, thereby allowing the yarn to be transferred at the points P1, P2, and P3 at a high speed. Appropriate guide plates are provided at the yarn transfer points P1, P2, and P3 to transfer the yarn from one yarn guide to another, but illustration thereof is omitted. For example, the guide plates are each shaped to instantly receive the yarn from the delivering-side yarn guide and to transfer it to the receiving-side yarn guide. - The present invention is not limited to the
oscillating arm member 35 that transfers the yarn during oscillation, but the delivering side arm may stop at the transfer position, while the receiving-side arm may start oscillation at this transfer position, so that the yarn is transported over the total oscillating range of the plurality of arms. - Figure 5 is a graph showing timings in a command voltage generated by each
control section 37 due to a command from themain control section 39 in Figure 4. - In the illustrated example, at a reference voltage (zero voltage), each
oscillating arm member 35 lies leftward. In response to an increase in voltage, theoscillating arm member 35 of the lefttraverse device unit 31 oscillates rightward from a turn position T1 and transfers, at the point P2, the yarn to theoscillating arm member 35 of the centraltraverse device unit 34. Theoscillating arm member 35 of the centraltraverse device unit 34 oscillates rightward and transfers, at the point P3, the yarn to theoscillating arm member 35 of the righttraverse device unit 32. Likewise, in response to an increase in voltage, theoscillating arm member 35 of the righttraverse device unit 32 moves to a turn position T2. Subsequently, in response to a voltage drop in each traverse device unit, the yarn is transferred from the turn position T2 to the turn position T1. Repeating the above operation allows the yarn Y to be traversed within the traverse range. - Thus, since the traverse range L in Figure 1 is divided, for example, into four, the oscillation range of the
oscillating arm member 35 of each of thetraverse device units 31 to 34 is narrowed to correspondingly enable theoscillating arm member 35 to be shortened. When theoscillating arm member 35 is shortened, inertia exerted during oscillation is diminished to enable the size of the entire traverse device to be reduced to accommodate high-speed turns. The length of theoscillating arm member 35 of each of the right and lefttraverse device units 31 and 32 (this length equals the distance from the oscillating shaft to the yarn guide) can also be reduced below that of each of the centraltraverse device units traverse device units 31 to 34 can be individually varied to shift the yarn transfer points P1, P2, and P3 in the traverse direction (the axial direction of the package) to hinder straight winding at these points P1, P2, and P3. - Figure 6 is a partial structural drawing of yet another traverse device. Two
traverse device units oscillating arm member 42 and a loweroscillating arm member 43, which are overlapping each other. In this case, a guide plate (not shown in the drawing) can be provided as appropriate to reliably transfer the yarn from the upperoscillating arm member 42 to the loweroscillating arm member 43. - In Figure 6, the upper
oscillating arm member 42, which is moving leftward to traverse the yarn Y, and the loweroscillating arm member 43, which is empty and is moving rightward to also traverse the yarn Y, transfer the yarn there between at the turn point T1 where they overlap each other. Since the loweroscillating arm member 43 reaches the turn point T1 while being accelerated, high-speed turns are achieved to more reliably prevent saddle bag shapes from being formed at the right and left ends. - As described above, according to the present invention, the yarn traverse range is determined by the oscillating range of the oscillating member, which is in turn determined by the control means for controlling the voice coil motor. Thus, by changing the oscillating range of the oscillating arm member, the traverse range can be gradually narrowed to easily wind the yarn into a tapered-end package or the traverse range can be periodically or non-periodically varied to carry out creeping to prevent saddle bag shapes.
- In addition, due to its simple mechanical configuration including the oscillating arm member and the voice coil motor that is driven normally and reversely, the present invention eliminates the needs for drive transmission means such as an endless belt to thereby improve durability while enabling the size of the entire traverse device to be reduced.
- Further, the voice coil motor that is subjected to a small inertia and that can be switched between normal and reverse driving at a high speed serves to achieve high-speed turns to enable accurate formation of packages in a predetermined form such as a tapered end while preventing saddle bag shapes.
- Alternatively, according to the present invention, the traverse range is divided into two or more so that the oscillating ranges of the two or more short oscillating arm members can be combined together to obtain a wide traverse range. The short oscillating arm members serve to reduce the inertia while increasing the turn speed, thereby enabling packages in an accurate form to be obtained while preventing saddle bag shapes. In addition, the number of oscillating arm members can be augmented to accommodate a wide traverse range.
- Alternatively, according to the present invention, by changing driving timings and/or driving ranges for the plurality of oscillating arm members, positions where the yarn is transferred between the oscillating arm members can be shifted to suppress straight winding at these transfer positions. As a result, despite the plurality of oscillating arm members, packages obtained each have an appropriate winding form.
- Alternatively, according to the present invention, the detection means can be used for feedback control to accurately control the traverse turn positions. Additionally, if the yarn is transferred between the plurality of oscillating arm members, the yarn transfer positions can be accurately controlled. As a result, packages obtained have an appropriate winding form, and the yarn can be reliably transferred to prevent winding errors.
Claims (12)
- A traverse device unit (1) comprising- an arm member (11),- a voice coil motor (12) comprising a stator (23) and a moveable member (24) surrounding the stator (23), and- a control means for controlling the voice coil motor (12),in which- said arm member (11) oscillating in a predetermined yarn traverse range (L), having a yarn guide (21) attached to one end, having its intermediate portion connected to a shaft (22) to oscillate around it and having the movable member (24) of the voice coil motor (12) connected to the other end,- said moveable member (24) being driven normally and reversely within a predetermined range, and- said stator (23) comprising a permanent magnet,characterized in that
a permanent magnet surface of said stator (23) which is opposed to said movable member (24) has N or S poles contiguously disposed in a driving direction of said movable member (24). - A traverse device unit (1) according to claim 1,
characterized in that
said permanent magnet is shaped like a fan extended around the shaft (22). - A traverse device unit (1) according to claim 1 or 2,
characterized in that
the stator (23) covers the normal and reverse driving range of the moveable member (24). - A traverse device unit (1) according to any one of preceding claims,
characterized in that
the moveable member (24) is sized to move along the stator (23). - A traverse device (30) comprising a plurality of traverse device units (31, 32, 33, 34) according to one of the claims 1 to 4, each of said traverse device units (31, 32, 33, 34) having an oscillating arm member (35),
characterized in that
said oscillating arm members (35) being arranged in a traverse direction so as to transfer a yarn between the adjacent oscillating arm members (35). - A traverse device according to claim 5,
characterized in that
two oscillating arm members (42, 43) are stacked at each traverse end in a direction of an oscillating shaft. - A traverse device according to any one of claims 5 or 6,
characterized in that
said control means (37, 39) individually controls oscillation of said plurality of oscillating arm members (35; 42, 43). - A traverse device according to claim 7,
characterized by
comprising detection means (38) for detecting positions at which said plurality of oscillating arm members are oscillated, said control means (37, 39) controlling oscillation of a receiving-side oscillating arm member depending on a detected oscillating position of a delivering-side oscillating arm member. - A traverse device according to any one of claims 5 to 8,
characterized in that
the oscillating arm members (35) arranged at the traverse ends are shorter than oscillating arm members arranged in a central portion of a traverse range. - A traverse device unit (1) according to one of the claims 1 to 4,
characterized in that
a command value to the voice coil motor (12) is changed to vary a position at which traversing is turned as winding progresses. - A traverse device unit (1) according to claim 10,
characterized in that
an amplitude of the command value to the voice coil motor (12) is periodically or non-periodically changed to vary the traverse turn position. - A traverse device (30) according to one of the claims 5 to 9,
characterized in that
the driving timings and/or driving ranges for the plurality of oscillating arm members (35; 42, 43) are changed to vary positions where the yarn is transferred between the oscillating members (35; 42, 43).
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP24702299A JP3292177B2 (en) | 1999-09-01 | 1999-09-01 | Traverse device |
| JP24702299 | 1999-09-01 |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP1081082A2 EP1081082A2 (en) | 2001-03-07 |
| EP1081082A3 EP1081082A3 (en) | 2002-06-05 |
| EP1081082B1 true EP1081082B1 (en) | 2006-07-26 |
Family
ID=17157250
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP20000118313 Expired - Lifetime EP1081082B1 (en) | 1999-09-01 | 2000-08-23 | Traverse device |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP1081082B1 (en) |
| JP (1) | JP3292177B2 (en) |
| DE (1) | DE60029523T2 (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN109205385A (en) * | 2018-07-24 | 2019-01-15 | 武汉船用机械有限责任公司 | A kind of pipe racking device |
Families Citing this family (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE10009611A1 (en) * | 2000-02-29 | 2001-08-30 | Schlafhorst & Co W | Device for controlling the thread tension of a running thread in an automatic winding device |
| FR2826644A1 (en) * | 2001-06-27 | 2003-01-03 | Rieter Icbt | GOING AND COMING MECHANISM FOR WIRE WINDING |
| ITMI20011851A1 (en) * | 2001-09-03 | 2003-03-03 | Sp El Srl | MAGNETIC WIRE GUIDE DEVICE AND EQUIPMENT FOR WINDING A WIRE ON CYLINDRICAL SUPPORTS |
| DE10152485B4 (en) * | 2001-10-24 | 2007-08-02 | Zimmer Ag | Traversing device |
| DE102005022448A1 (en) * | 2005-05-14 | 2006-11-16 | Saurer Gmbh & Co. Kg | Thread laying drive, especially for working station of textile machine, has controller comprising multivariable control system to accurately control actual angular position of thread guide by at least one correcting variable |
| JP2006335483A (en) * | 2005-05-31 | 2006-12-14 | Murata Mach Ltd | Yarn traverse device, and textile machine therewith |
| KR101329103B1 (en) * | 2009-01-16 | 2013-11-14 | 티엠티 머시너리 가부시키가이샤 | Yarn winding device and spinning machine |
| JP2012224436A (en) * | 2011-04-19 | 2012-11-15 | Murata Machinery Ltd | Yarn winding machine |
| DE102014208336A1 (en) * | 2014-05-05 | 2015-11-05 | Schaeffler Technologies AG & Co. KG | Traversing drive |
| CN105151895B (en) * | 2015-08-06 | 2017-12-08 | 盐城金大纺织机械制造有限公司 | A kind of tube take-up |
| JP2020147382A (en) * | 2019-03-11 | 2020-09-17 | 村田機械株式会社 | Yarn winding machine and yarn winding method |
| CN112340532A (en) * | 2020-03-31 | 2021-02-09 | 连江明杰信息技术有限公司 | Rope device is received in construction |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5523911A (en) * | 1991-08-29 | 1996-06-04 | Hitachi Metals, Ltd. | Minimum bearing load, high precision actuator arm with force couple actuation |
| JPH08217332A (en) * | 1995-02-16 | 1996-08-27 | Murata Mach Ltd | Yarn traverse device |
| CH693094A5 (en) * | 1998-10-28 | 2003-02-28 | Rieter Ag Maschf | Traversing unit. |
| DE19858548A1 (en) * | 1998-12-18 | 2000-06-21 | Schlafhorst & Co W | Electromechanical drive for the reciprocating yarn guide for winding cross wound bobbins has a structured air gap with magnetic field lines through it acting on a coil at the yarn guide |
-
1999
- 1999-09-01 JP JP24702299A patent/JP3292177B2/en not_active Expired - Fee Related
-
2000
- 2000-08-23 DE DE2000629523 patent/DE60029523T2/en not_active Expired - Lifetime
- 2000-08-23 EP EP20000118313 patent/EP1081082B1/en not_active Expired - Lifetime
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN109205385A (en) * | 2018-07-24 | 2019-01-15 | 武汉船用机械有限责任公司 | A kind of pipe racking device |
| CN109205385B (en) * | 2018-07-24 | 2020-08-07 | 武汉船用机械有限责任公司 | a pipe arrangement |
Also Published As
| Publication number | Publication date |
|---|---|
| EP1081082A3 (en) | 2002-06-05 |
| EP1081082A2 (en) | 2001-03-07 |
| DE60029523D1 (en) | 2006-09-07 |
| DE60029523T2 (en) | 2007-08-09 |
| JP3292177B2 (en) | 2002-06-17 |
| JP2001072334A (en) | 2001-03-21 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US6311919B1 (en) | Yarn guide for the traversing delivery of a yarn to a rotationally driven takeup bobbin | |
| EP1081082A2 (en) | Traverse device and method | |
| CN1191187C (en) | A yarn guide for traversing the yarn onto a rotating bobbin | |
| JP4155705B2 (en) | Yarn transfer method and traverse device | |
| CN1332867C (en) | Traverse controlling device | |
| EP2765102B1 (en) | Method for distributing wound yarn and device for carrying it out | |
| JP2004527431A (en) | Reciprocating device for winding yarn in package form | |
| AU2004203882A1 (en) | Electric motor, lift with a cage movable by an electric motor, and lift with a cage and with an electric motor for movement of a guide element relative to the cage | |
| CN101104487A (en) | High-frequency thread-guide device for the production of bobbins with modulated traversing | |
| US6825582B2 (en) | Linear motor drive unit for a machine | |
| JP2002528358A (en) | Yarn traverse device | |
| JP2001240310A (en) | Device for controlling string tension of string traveling on automatic winder | |
| EP0066128B1 (en) | Device for forming yarn packages | |
| CN101318599B (en) | Yarn guiding mechanism on textile machines | |
| JP2001261234A (en) | Traversing device and traversing method | |
| EP0353074B1 (en) | Step linear actuator | |
| CN105517931B (en) | Apply yarn equipment and bobbin-winding machine | |
| JP2003012228A (en) | Reciprocal traverse device and reciprocal traversing method | |
| NL1002036C1 (en) | Spool winding machine or machine bank | |
| JPH07137935A (en) | Continuous reciprocating device | |
| JPH0477547B2 (en) | ||
| JPH07137934A (en) | Yarn traversing device using linear motor | |
| KR20220033452A (en) | Yarn winding machine | |
| JP5026559B2 (en) | Linear motor control device | |
| GB2026795A (en) | Control of stepper motors |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A2 Designated state(s): AT BE CH CY DE DK ES FI FR GB GR IE IT LI LU MC NL PT SE |
|
| AX | Request for extension of the european patent |
Free format text: AL;LT;LV;MK;RO;SI |
|
| PUAL | Search report despatched |
Free format text: ORIGINAL CODE: 0009013 |
|
| AK | Designated contracting states |
Kind code of ref document: A3 Designated state(s): AT BE CH CY DE DK ES FI FR GB GR IE IT LI LU MC NL PT SE |
|
| AX | Request for extension of the european patent |
Free format text: AL;LT;LV;MK;RO;SI |
|
| 17P | Request for examination filed |
Effective date: 20020916 |
|
| AKX | Designation fees paid |
Designated state(s): DE IT |
|
| 17Q | First examination report despatched |
Effective date: 20030617 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| RTI1 | Title (correction) |
Free format text: TRAVERSE DEVICE |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): DE IT |
|
| REF | Corresponds to: |
Ref document number: 60029523 Country of ref document: DE Date of ref document: 20060907 Kind code of ref document: P |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed |
Effective date: 20070427 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20090820 Year of fee payment: 10 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100823 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20120822 Year of fee payment: 13 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20140301 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R119 Ref document number: 60029523 Country of ref document: DE Effective date: 20140301 |