EP0433892A1 - A linkage system for making an equipment translate parallely to itself, such equipment being carried by an excavator or by a basic machine - Google Patents
A linkage system for making an equipment translate parallely to itself, such equipment being carried by an excavator or by a basic machine Download PDFInfo
- Publication number
- EP0433892A1 EP0433892A1 EP90124091A EP90124091A EP0433892A1 EP 0433892 A1 EP0433892 A1 EP 0433892A1 EP 90124091 A EP90124091 A EP 90124091A EP 90124091 A EP90124091 A EP 90124091A EP 0433892 A1 EP0433892 A1 EP 0433892A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- equipment
- machine
- hinged
- linkage system
- linkage
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
- 239000012530 fluid Substances 0.000 claims description 2
- 238000005553 drilling Methods 0.000 description 3
- 230000004075 alteration Effects 0.000 description 1
- 238000010276 construction Methods 0.000 description 1
- 238000003466 welding Methods 0.000 description 1
Images

Classifications
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F3/00—Dredgers; Soil-shifting machines
- E02F3/04—Dredgers; Soil-shifting machines mechanically-driven
- E02F3/28—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets
- E02F3/30—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom
- E02F3/302—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom with an additional link
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F3/00—Dredgers; Soil-shifting machines
- E02F3/04—Dredgers; Soil-shifting machines mechanically-driven
- E02F3/28—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets
- E02F3/30—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom
- E02F3/308—Dredgers; Soil-shifting machines mechanically-driven with digging tools mounted on a dipper- or bucket-arm, i.e. there is either one arm or a pair of arms, e.g. dippers, buckets with a dipper-arm pivoted on a cantilever beam, i.e. boom working outwardly
Definitions
- This invention refers to a linkage system for making an equipment translate parallely to itself, such equipment being carried by an exacavator or by a basic machine. More specifically the invention refers to an articulated parallelogram linkage system connecting drilling and other similar equipments with the machine carrying them.
- the mast of the equipment is known to be connected with the machine by means of an articulated linkage system which makes it translate, keeping the equipment consistently parallel to its own original position.
- linkages usually consist of bars, frames and pistons combined in such a way as to keep a constant parallelism of the equipment while the geometry of the linkage changes during the various movements of the equipment.
- Another drawback can be the fact that such a connection can alter the properties of the frame on which it is welded, making it weaker or at least making the original structure less reliable as a whole.
- the purpose of this invention is to obviate the above mentioned drawbacks by proposing a linkage system allowing to keep the structure of new or existing multi-purpose commercial machines unvaried, as two hinging points are sufficient to carry the equipment.
- this invention proposes to realize a linkage system connecting an equipment and an excavator or a basic machine by which such linkage is carried, characterized in that the linkage is quadrilateral so as to translate said equipment parallely to itself; the linkage consisting of at least one rigid connecting element between the machine and the equipment and at least one piston-like actuating element for said rigid element; the elements forming the linkage system or part of them being connected with the machine along no more than two separate and substantially parallel hinge axles.
- a basic machine 10 carries a drilling equipment generally indicated by 11, which is moreover connected to the basic machine 10 by means of a linkage 12 that allows the equipment 11 to translate parallely to itself, as shown clearly by the figures.
- Linkage 12 consists of a rigid boom 13, a rigid bar 14 and a piston 15. Boom 13 and bar 14 are hinged respectively in 16 and 17 to a frame 18, which in turn is hinged in 19 to the mast of equipment 11.
- Stem 21 of piston 15 is hinged in an intermediate point 20 of boom 13.
- boom 13 is hinged in 22 to the basic machine 10, while bar 14 and piston 15 are hinged along one hinge axle 23 to the same machine 10.
- FIG. 2 A preferential but not limitative configuration of this hinging system is shown by fig. 2, consisting of two side-mounted bars 14, rigidly joined by a cross-member 24 with respective fork-extensions 25. These have their ends connected to flanges 26 of the machine 10 and to lugs 27 of two side-mounted pistons 15 that pivot on the same shaft through pins 23.
- actuators 40 and 15 of fig. 5 are series connected through an incompressible fluid in such a way that if an actuator , for example 40, is expanded, the second actuator 15 is automatically forced by the first one to expand too, thus generating the parallel motion.
- the pivoting points of unit 12 to machine 10 are realized only along two horizontal axles 22 and 23, which, in the case of an existing machine such as a commercial excavator , are the hinging points provided for the attachment of the equipment that can be mounted on the machine. Consequently, the machine does not require any supplementary adapting parts, such as brackets to be welded on for extra hinge axles.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Mining & Mineral Resources (AREA)
- Civil Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Structural Engineering (AREA)
- Earth Drilling (AREA)
Abstract
Description
- This invention refers to a linkage system for making an equipment translate parallely to itself, such equipment being carried by an exacavator or by a basic machine. More specifically the invention refers to an articulated parallelogram linkage system connecting drilling and other similar equipments with the machine carrying them. The mast of the equipment is known to be connected with the machine by means of an articulated linkage system which makes it translate, keeping the equipment consistently parallel to its own original position.
- These linkages usually consist of bars, frames and pistons combined in such a way as to keep a constant parallelism of the equipment while the geometry of the linkage changes during the various movements of the equipment.
- In common systems, two axles of the hinges of the linkage plus an axle of the piston hinge are realized on the excavator or on the basic machine.
- When a mass produced hydraulic machine or excavator is being used, problems arise for there are usually only two hinge points, respectively one for the movements of a boom and the other for the actuator/s. This is the typical example of a boom excavator.
- It is therefore obvious that the mounting of a drilling machine equipped with a linkage system is subject to the construction of a third pivoting point on the basic machine frame. This is hard work, in that the hinge support must almost always be welded, with a consequent alteration of the basic structure of the machine.
- The mounting operation on second-hand or new commercial equipped machines becomes even more complicated, in that the welding of the third hinge cannot be provided on the site and quite often requires the facilities of a good workshop.
- Moreover, the need for another hinge point can cause troubles, should one ever require to reconvert the basic machine to its original function.
- Another drawback can be the fact that such a connection can alter the properties of the frame on which it is welded, making it weaker or at least making the original structure less reliable as a whole.
- The purpose of this invention is to obviate the above mentioned drawbacks by proposing a linkage system allowing to keep the structure of new or existing multi-purpose commercial machines unvaried, as two hinging points are sufficient to carry the equipment.
- For these and for other purposes which will be better understood further on, this invention proposes to realize a linkage system connecting an equipment and an excavator or a basic machine by which such linkage is carried, characterized in that the linkage is quadrilateral so as to translate said equipment parallely to itself; the linkage consisting of at least one rigid connecting element between the machine and the equipment and at least one piston-like actuating element for said rigid element; the elements forming the linkage system or part of them being connected with the machine along no more than two separate and substantially parallel hinge axles.
- We are now going to describe the subject of the invention referring to a few configurations which are, however, of equivalent validity, as being based on the same innovating principle.
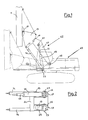
- Fig. 1
- is the side view of the machine with an equipment and a linkage system according to this invention in a first configuration and with the equipment shown in two different operating positions.
- Fig. 2
- is a sectional view of the linkage of fig.1 illustrating some top-view details.
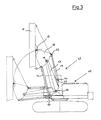
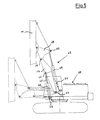
- Figs. 3, 4 and 5
- are views like fig. 1 of three further configurations of the linkage system according to this invention.
- First of all, reference is made to the configuration illustrated in figs. 1 and 2.
- A
basic machine 10 carries a drilling equipment generally indicated by 11, which is moreover connected to thebasic machine 10 by means of alinkage 12 that allows theequipment 11 to translate parallely to itself, as shown clearly by the figures. - We point out that we always refer to single parts as they are side-view represented, but obviously each part that is described is intended to have an equivalent side-mounted part so as to provide stability and reliability to the whole structure.
Linkage 12 consists of arigid boom 13, arigid bar 14 and apiston 15.Boom 13 andbar 14 are hinged respectively in 16 and 17 to aframe 18, which in turn is hinged in 19 to the mast ofequipment 11. -
Stem 21 ofpiston 15 is hinged in anintermediate point 20 ofboom 13. - The other end of
boom 13 is hinged in 22 to thebasic machine 10, whilebar 14 andpiston 15 are hinged along onehinge axle 23 to thesame machine 10. - A preferential but not limitative configuration of this hinging system is shown by fig. 2, consisting of two side-mounted
bars 14, rigidly joined by across-member 24 with respective fork-extensions 25. These have their ends connected toflanges 26 of themachine 10 and to lugs 27 of two side-mountedpistons 15 that pivot on the same shaft throughpins 23. - As to the configuration shown by fig. 3, the same reference numbers have been used for the parts corresponding to the ones already described in fig. 1 ; this will apply also to the other configurations, illustrated by figs. 4 and 5.
- The substantial difference between the configuration of fig. 3 and that of figs. 1 and 2, is that
piston 15 is now hinged in 30 to alug 31 ofboom 13, instead of being pivotally connected inhinge 23 ofbar 14 ;stem 21 ofpiston 15 is hinged in 32 directly toframe 18 instead ofboom 13. - The configuration shown by fig. 4 is different from the previous ones in that
piston 15 is pivoting in 33 of alug 34 ofbar 14, whilestem 21 is hinged in 20 toboom 13, as it is in the case of the embodiment shown by fig. 1. - Finally, in the configuration of fig. 5,
bar 14 has been replaced by asecond piston 40 therefore an ibrid solution results thereof, where: thefirst piston 15 as per fig. 3 is hinged in 30 toboom 13 and in 32 toframe 18; thesecond piston 40 is hinged with itsstem 42 toboom 13 and in 23 to themachine 10, in the same way aspiston 15 was hinged as per the embodiment shown by fig.1. - According to a favourite configuration,
actuators second actuator 15 is automatically forced by the first one to expand too, thus generating the parallel motion. - In all the above mentioned cases, the pivoting points of
unit 12 tomachine 10 are realized only along twohorizontal axles - Should the machines be new, of course, the solution herein proposed by this invention allows to realize them in a simple way from the beginning, that is with only two hinge axles, as is normally required for all traditional equipments designed for being mounted on this kind of machines.
Claims (6)
- A linkage system (12) connecting an equipment (11) and an excavator or a basic machine (10) by which such linkage is carried, characterized in that the linkage (12) is quadrilateral so as to translate said equipment (11) parallely to itself; the linkage consisting of at least one rigid element (13) connecting the machine (10) and the equipment (11) and at least one piston-like actuating element (15) for said rigid element (13); the elements forming the linkage system (13,14,15,40) or part of them being connected with the machine (10) along no more than two separate and substantially parallel hinge axles (22,23).
- A linkage system according to claim 1 characterized in that it is formed by a rigid boom (13) and a rigid bar (14) hinged to their ends respectively (16,17) to a frame (18), in turn hinged (19) to the equipment (11) and to said hinge axles (22, 23,) of the machine (10).
- A linkage system according to claim 2 characterized in that the actuating element (15) is hinged on one end (20) to boom (13) and on the other end to the hinge axle (23) of bar (14) on the machine (10).
- A linkage system according to claim 2 characterized in that the actuating element (15) is hinged on one end (32) to the frame (18) and on the other end (30) along boom (13).
- A linkage system according to claim 2 characterized in that the actuating element (15) is hinged on one end (20) along boom (13) and on the other end (33) along the bar (14).
- A linkage system according to claim 1 characterized in that it is formed by a rigid boom (13) and by two actuating elements (15, 40); boom (13) being hinged on one end (16) to the frame (18) and on the other end to one of the hinge axles (22) of the machine, one of the actuating elements (15) being hinged (32) respectively to the frame (18) and along boom (13) and the other one (40) being hinged (41) along boom (13) and to the second of the hinge axles (23) of the machine; the actuating elements (15,40) being series connected to one another by an incompressible fluid in such a way that, if one of the actuating elements is expanded, the second actuating element is forced by the first one to expand and viceversa, generating the parallelogram system.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| IT05356189U IT222543Z2 (en) | 1989-12-19 | 1989-12-19 | QUADRILATER KINEMATIC GROUP FOR THE TRANSLATION PARALLELLY TO ITSELF OF AN ACTUATOR GROUP CARRIED BY AN EXCAVATOR OR A BASIC MACHINE. |
| IT5356189U | 1989-12-19 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP0433892A1 true EP0433892A1 (en) | 1991-06-26 |
| EP0433892B1 EP0433892B1 (en) | 1996-03-06 |
Family
ID=11283696
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP90124091A Expired - Lifetime EP0433892B1 (en) | 1989-12-19 | 1990-12-13 | A linkage system for making an equipment translate parallely to itself, such equipment being carried by an excavator or by a basic machine |
Country Status (4)
| Country | Link |
|---|---|
| EP (1) | EP0433892B1 (en) |
| DE (1) | DE69025729T2 (en) |
| ES (1) | ES2084640T3 (en) |
| IT (1) | IT222543Z2 (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US11459826B2 (en) | 2018-01-16 | 2022-10-04 | Soilmec S.P.A. | Assembly for moving excavation or drilling equipment and actuating method therefor |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4103791A (en) * | 1977-06-03 | 1978-08-01 | Harnischfeger Corporation | Shovel attachment means for hydraulic excavator |
| US4364705A (en) * | 1980-07-07 | 1982-12-21 | J. I. Case Company | Loader mechanism |
| FR2537183A1 (en) * | 1982-12-06 | 1984-06-08 | Orenstein & Koppel Ag | MECHANICAL SHOVEL BOWL |
-
1989
- 1989-12-19 IT IT05356189U patent/IT222543Z2/en active IP Right Grant
-
1990
- 1990-12-13 ES ES90124091T patent/ES2084640T3/en not_active Expired - Lifetime
- 1990-12-13 DE DE69025729T patent/DE69025729T2/en not_active Expired - Fee Related
- 1990-12-13 EP EP90124091A patent/EP0433892B1/en not_active Expired - Lifetime
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4103791A (en) * | 1977-06-03 | 1978-08-01 | Harnischfeger Corporation | Shovel attachment means for hydraulic excavator |
| US4364705A (en) * | 1980-07-07 | 1982-12-21 | J. I. Case Company | Loader mechanism |
| FR2537183A1 (en) * | 1982-12-06 | 1984-06-08 | Orenstein & Koppel Ag | MECHANICAL SHOVEL BOWL |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US11459826B2 (en) | 2018-01-16 | 2022-10-04 | Soilmec S.P.A. | Assembly for moving excavation or drilling equipment and actuating method therefor |
Also Published As
| Publication number | Publication date |
|---|---|
| ES2084640T3 (en) | 1996-05-16 |
| IT8953561V0 (en) | 1989-12-19 |
| IT8953561U1 (en) | 1991-06-19 |
| DE69025729T2 (en) | 1996-07-25 |
| EP0433892B1 (en) | 1996-03-06 |
| DE69025729D1 (en) | 1996-04-11 |
| IT222543Z2 (en) | 1995-04-21 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US7818901B2 (en) | Progressive linkage for excavator thumb | |
| EP3612683B1 (en) | Loader lift arm assembly for a power machine | |
| US10316488B2 (en) | Universal backhoe coupler | |
| GB2333760A (en) | Method of visibly ensuring quick coupling | |
| EP0478749A1 (en) | Ripper assembly with pitch control and integral frame and push block. | |
| US4087009A (en) | Backhoe frame | |
| US4486141A (en) | Linkage system for a loader vehicle | |
| DE4208245A1 (en) | Interchangeable jib arm arrangement for excavator - has basic arm and hydraulic cylinder connecting plate located for attachment of tool arm or specialist function sections. | |
| DE69804798T2 (en) | FRAME ARRANGEMENT FOR A WORKING MACHINE AND RELATED METHOD FOR THEIR PRODUCTION | |
| US4337837A (en) | Mounting mechanism for angle dozer blade | |
| US3749182A (en) | Angle and tilt mechanism for bulldozer | |
| US3784162A (en) | Scissor hoist | |
| EP0433892B1 (en) | A linkage system for making an equipment translate parallely to itself, such equipment being carried by an excavator or by a basic machine | |
| DE69808910T2 (en) | KIPPGESTÄNGEANORDNUNG | |
| US4113031A (en) | Power shift mechanism for earth working implements | |
| US3452882A (en) | Swing mechanism for backhoes | |
| JP2771121B2 (en) | Snow removal equipment | |
| GB2212132A (en) | Apparatus for a folding-down loader tailboard | |
| DE2357365B2 (en) | Boom linkage | |
| US5266001A (en) | Working machine for construction vehicles and method of operating the same | |
| US4725187A (en) | Excavator | |
| US4244429A (en) | Mounting mechanism for angle dozer blade | |
| DE19746702A1 (en) | Pivoting adaptor for attachment of tool to end of shovel arm | |
| EP0399043B1 (en) | Method of operating a working machine for construction vehicles | |
| RU2082854C1 (en) | Grab |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): BE DE ES FR GB IT NL |
|
| 17P | Request for examination filed |
Effective date: 19911009 |
|
| 17Q | First examination report despatched |
Effective date: 19930730 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): BE DE ES FR GB IT NL |
|
| REF | Corresponds to: |
Ref document number: 69025729 Country of ref document: DE Date of ref document: 19960411 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 2084640 Country of ref document: ES Kind code of ref document: T3 |
|
| ITF | It: translation for a ep patent filed | ||
| ET | Fr: translation filed | ||
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed | ||
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: IF02 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20071217 Year of fee payment: 18 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: NL Payment date: 20081203 Year of fee payment: 19 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20090120 Year of fee payment: 19 Ref country code: FR Payment date: 20081212 Year of fee payment: 19 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20081211 Year of fee payment: 19 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20081210 Year of fee payment: 19 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: BE Payment date: 20090112 Year of fee payment: 19 |
|
| BERE | Be: lapsed |
Owner name: *SOILMEC S.P.A. Effective date: 20091231 |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: V1 Effective date: 20100701 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20091213 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST Effective date: 20100831 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20091231 Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20091231 Ref country code: NL Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100701 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20100701 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20091213 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FD2A Effective date: 20110228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF EXPIRATION OF PROTECTION Effective date: 20101214 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20081213 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF EXPIRATION OF PROTECTION Effective date: 20091214 |