CN218100477U - Triaxial motion control software training platform - Google Patents
Triaxial motion control software training platform Download PDFInfo
- Publication number
- CN218100477U CN218100477U CN202222222003.2U CN202222222003U CN218100477U CN 218100477 U CN218100477 U CN 218100477U CN 202222222003 U CN202222222003 U CN 202222222003U CN 218100477 U CN218100477 U CN 218100477U
- Authority
- CN
- China
- Prior art keywords
- frame
- lifting
- moving
- screw
- axis motion
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images


Landscapes
- Toys (AREA)
Abstract
本实用新型公开了一种三轴运动控制软件实训平台,包括机架,所述机架的侧壁为开口状,所述机架的内顶壁上安装有驱动电机,所述机架的顶部设有两个间隔设置的滑动壳;还包括:移动件,设有两个,两个移动件位于驱动电机的两侧,且每个所述移动件均与一个滑动壳转动连接;升降件,架设在机架的上方,且所述升降件底部的两端分别套设在两个移动件上;夹持件,套设在升降件上,且所述夹持件位于机架的上方,每个所述移动件均包括移动螺杆,所述移动螺杆水平位于一个滑动壳内。该当三轴运动控制软件实训平台,能够实现三轴运动,并且通过夹持件,通过夹持物体,使学生更加直观的观察三轴运动,便于理解三轴运动。
The utility model discloses a three-axis motion control software training platform, which comprises a frame, the side wall of the frame is open, a driving motor is installed on the inner top wall of the frame, and the There are two sliding shells arranged at intervals on the top; it also includes: two moving parts, the two moving parts are located on both sides of the drive motor, and each of the moving parts is rotatably connected with a sliding shell; the lifting part , erected on the top of the frame, and the two ends of the bottom of the lifting part are respectively sleeved on the two moving parts; the clamping part is set on the lifting part, and the clamping part is located above the frame, Each of the moving parts includes a moving screw horizontally located in a sliding housing. It should be a three-axis motion control software training platform, which can realize three-axis motion, and through the clamping parts and clamping objects, students can observe the three-axis motion more intuitively and understand the three-axis motion easily.
Description
技术领域technical field
本实用新型涉及三轴运动平台技术领域,具体为一种三轴运动控制软件实训平台。The utility model relates to the technical field of three-axis motion platforms, in particular to a three-axis motion control software training platform.
背景技术Background technique
三轴运动平台为XYZ三轴直线运动模组,三轴运动平台随着自动化的快速发展,广泛引用于喷漆、组装和点胶等作业当中,同时在现在机电一体化专业教学中,三轴运动控制软件实训平台亦能够快速的使学员掌控PLC编程,但现有的三轴运动控制软件实训平台在使用过程中仍存在一些不足。The three-axis motion platform is an XYZ three-axis linear motion module. With the rapid development of automation, the three-axis motion platform is widely used in painting, assembly and dispensing operations. At the same time, in the current mechatronics professional teaching, three-axis motion The control software training platform can also quickly enable students to master PLC programming, but the existing three-axis motion control software training platform still has some shortcomings in the process of use.
如公开号为CN205810236U的三轴联动实训平台,包括控制箱和平台底座;控制箱包括PLC控制器;平台底座上设置有X轴运动装置、Y轴运动装置和Z轴运动装置;X轴运动装置、Y轴运动装置和Z轴运动装置分别与PLC控制器电连接;X轴运动装置包括X轴丝杠,Y轴运动装置设置在X轴丝杠上,且Y轴运动装置能够沿X轴丝杠的轴向往复运动;Y轴运动装置包括Y轴丝杠;Z轴运动装置设置在Y轴丝杠上,但是其在使用过程中,画笔组件仅能在平面进行描绘,所描绘的运动轨迹不够全面,无法使学生能够直面的观察全部三轴运动轨迹,对于学生来说,学习效率低,无法快速掌握编程技能。For example, the three-axis linkage training platform whose publication number is CN205810236U includes a control box and a platform base; the control box includes a PLC controller; the platform base is provided with an X-axis motion device, a Y-axis motion device, and a Z-axis motion device; the X-axis motion The device, the Y-axis motion device and the Z-axis motion device are respectively electrically connected to the PLC controller; the X-axis motion device includes an X-axis screw, and the Y-axis motion device is arranged on the X-axis screw, and the Y-axis motion device can move along the X-axis The axial reciprocating motion of the screw; the Y-axis motion device includes the Y-axis screw; the Z-axis motion device is set on the Y-axis screw, but during its use, the brush assembly can only be drawn on a plane, and the depicted motion The trajectory is not comprehensive enough to enable students to observe all three-axis motion trajectories directly. For students, the learning efficiency is low and they cannot quickly master programming skills.
所以我们提出了一种三轴运动控制软件实训平台,以便于解决上述中提出的问题。So we propose a three-axis motion control software training platform in order to solve the problems raised above.
实用新型内容Utility model content
本实用新型的目的在于提供一种三轴运动控制软件实训平台,以解决上述背景技术提出的目前市场上三轴运动控制软件实训平台,画笔组件仅能在平面进行描绘,所描绘的运动轨迹不够全面,无法使学生能够直面的观察全部三轴运动轨迹,对于学生来说,学习效率低,无法快速掌握编程技能的问题。The purpose of this utility model is to provide a kind of three-axis motion control software training platform, to solve the current three-axis motion control software training platform on the market proposed by the above-mentioned background technology, the brush assembly can only be described on the plane, and the described motion The trajectories are not comprehensive enough to enable students to observe all three-axis motion trajectories directly. For students, the learning efficiency is low and they cannot quickly master programming skills.
为实现上述目的,本实用新型提供如下技术方案:一种三轴运动控制软件实训平台,包括机架,所述机架的侧壁为开口状,所述机架的内顶壁上安装有驱动电机,所述机架的顶部设有两个间隔设置的滑动壳;In order to achieve the above purpose, the utility model provides the following technical solutions: a three-axis motion control software training platform, including a frame, the side wall of the frame is open, and the inner top wall of the frame is installed with Drive motor, the top of the frame is provided with two sliding shells arranged at intervals;
还包括:Also includes:
移动件,设有两个,两个移动件位于驱动电机的两侧,且每个所述移动件均与一个滑动壳转动连接;There are two moving parts, the two moving parts are located on both sides of the drive motor, and each of the moving parts is rotatably connected to a sliding shell;
升降件,架设在机架的上方,且所述升降件底部的两端分别套设在两个移动件上;The lifting part is erected above the frame, and the two ends of the bottom of the lifting part are respectively sleeved on the two moving parts;
夹持件,套设在升降件上,且所述夹持件位于机架的上方。The clamping piece is sleeved on the lifting piece, and the clamping piece is located above the frame.
优选的,每个所述移动件均包括移动螺杆,所述移动螺杆水平位于一个滑动壳内,且所述移动螺杆的一端与滑动壳的一内侧壁转动连接,移动螺杆的另一端贯穿滑动壳的另一内侧壁并延伸出去,所述机架的内顶壁上转动设有同步轴,且所述同步轴与移动螺杆的另一端传动连接,所述驱动电机的输出端与两个同步轴传动连接。Preferably, each of the moving parts includes a moving screw, the moving screw is horizontally located in a sliding shell, and one end of the moving screw is rotatably connected to an inner sidewall of the sliding shell, and the other end of the moving screw runs through the sliding shell The other inner wall of the frame extends out, and the inner top wall of the frame is rotated with a synchronous shaft, and the synchronous shaft is connected with the other end of the moving screw, and the output end of the driving motor is connected with the two synchronous shafts. Drive connection.
通过采用上述技术方案,当三轴运动控制软件实训平台使用时,驱动电机带动两个同步轴转动,同步轴带动移动螺杆转动,能够使两个移动螺杆同步转动,使套设在其上的升降件进行X轴直线运动。By adopting the above technical scheme, when the three-axis motion control software training platform is used, the driving motor drives the two synchronous shafts to rotate, and the synchronous shaft drives the moving screw to rotate, so that the two moving screws can rotate synchronously, so that the The lifting part performs X-axis linear motion.
优选的,所述升降件包括安装辊,所述安装辊设有两个,两个安装辊间隔竖直位于机架的顶部,两个所述安装辊的底端分别套设在两个移动螺杆上,两个所述安装辊的顶部水平设有横架,每个所述安装辊内均转动设有升降螺杆,每个所述升降螺杆的顶端均贯穿一个安装辊并延伸出去,所述横架内水平转动设有转动辊,且所述转动辊位于两个升降螺杆的上方。Preferably, the lifting member includes two installation rollers, the two installation rollers are vertically located on the top of the frame at intervals, and the bottom ends of the two installation rollers are respectively sleeved on two moving screw rods Above, the tops of the two installation rollers are horizontally provided with horizontal frames, and each of the installation rollers is rotated with a lifting screw, and the top of each of the lifting screws passes through one installation roller and extends out. A rotating roller is provided for horizontal rotation in the frame, and the rotating roller is located above the two lifting screws.
通过采用上述技术方案,当三轴运动控制软件实训平台使用时,升降电机带动转动辊转动,使主动伞齿随之转动,带动与其啮合的从动伞齿转动,使两个升降螺杆转动,套设在其上的升降架进行Y轴直线运动。By adopting the above technical scheme, when the three-axis motion control software training platform is used, the lifting motor drives the rotating roller to rotate, so that the active bevel gear rotates accordingly, and drives the driven bevel gear meshed with it to rotate, so that the two lifting screws rotate, The lifting frame sleeved on it performs Y-axis linear motion.
优选的,每个所述升降螺杆的顶端均设有从动伞齿,所述转动辊上间隔套设有两个主动伞齿,且每个所述主动伞齿均与一个从动伞齿相啮合,所述横架的侧壁上安装有升降电机,且所述升降电机的输出端贯穿横架与转动辊固定连接。Preferably, a driven bevel tooth is provided on the top of each lifting screw, two driving bevel teeth are spaced on the rotating roller, and each of the driving bevel teeth is connected to a driven bevel tooth. Engaging, the side wall of the horizontal frame is equipped with a lifting motor, and the output end of the lifting motor passes through the horizontal frame and is fixedly connected with the rotating roller.
通过采用上述技术方案,当三轴运动控制软件实训平台使用时,升降电机通过转动辊带动两个主动伞齿转动,使两个主动伞齿带动两个从动伞齿转动,使两个升降螺杆同步转动,移动更加平滑。By adopting the above technical scheme, when the three-axis motion control software training platform is used, the lifting motor drives the two driving bevel teeth to rotate through the rotating roller, so that the two driving bevel teeth drive the two driven bevel teeth to rotate, so that the two lifting The screws rotate synchronously for smoother movement.
优选的,所述夹持件包括升降架,所述升降架套设在两个升降螺杆上,且所述升降架内转动设有旋转螺杆,所述旋转螺杆上套设有滑动块,且所述滑动块与升降架滑动连接,所述滑动块上安装有移动块,且所述移动块呈冂字形结构设置,所述移动块内设有驱动齿轮,且所述驱动齿轮为双层结构,所述驱动齿轮的下段直径大于驱动齿轮上段的直径,所述移动块内设有与其转动连接的转动轴,所述移动块的侧壁上安装有输出端与驱动齿轮固定连接的夹持电机,所述升降架上安装有输出端与旋转螺杆固定连接的旋转电机。Preferably, the clamping member includes a lifting frame, the lifting frame is sleeved on two lifting screws, and a rotating screw is rotated in the lifting frame, a sliding block is sleeved on the rotating screw, and the The sliding block is slidably connected with the lifting frame, a moving block is installed on the sliding block, and the moving block is arranged in a Z-shaped structure, a driving gear is arranged inside the moving block, and the driving gear is a double-layer structure, The diameter of the lower section of the driving gear is greater than the diameter of the upper section of the driving gear. A rotating shaft connected to the moving block is provided in the moving block. A clamping motor whose output end is fixedly connected with the driving gear is installed on the side wall of the moving block. A rotary motor whose output end is fixedly connected with the rotary screw rod is installed on the lifting frame.
通过采用上述技术方案,当三轴运动控制软件实训平台使用时,旋转电机带动旋转螺杆转动,滑动块沿旋转螺杆的长度方向进行移动,带动移动块移动,进行Z轴直线移动,夹持电机带动驱动齿轮转动,并通过驱动齿轮带动两个斜臂以转动轴为轴心进行转动。By adopting the above technical scheme, when the three-axis motion control software training platform is used, the rotating motor drives the rotating screw to rotate, and the sliding block moves along the length direction of the rotating screw, driving the moving block to move in a Z-axis linear motion, and clamping the motor Drive the driving gear to rotate, and drive the two oblique arms to rotate with the rotating shaft as the axis through the driving gear.
优选的,所述转动轴上套设有两个间隔设置的斜臂,且两个所述斜臂相贴合,每个所述斜臂的顶端均设有与驱动齿轮相啮合的弧形齿条,且两个所述弧形齿条分别位于驱动齿轮的上方与下方。Preferably, two slanted arms arranged at intervals are sleeved on the rotating shaft, and the two slanted arms are fitted together, and the top of each of the slanted arms is provided with an arc-shaped tooth that meshes with the drive gear bar, and the two arc-shaped racks are respectively located above and below the drive gear.
通过采用上述技术方案,当三轴运动控制软件实训平台使用时,转动的驱动齿轮带动两个与其啮合的弧形齿条移动,从而使两个弧形齿条带动斜臂进一转动轴为轴心进行转动,通过斜臂将物品夹持起来,进行移动,从而实现三轴直线运动的轨迹展示,使得三轴运动观察起来更加直观,便于理解。By adopting the above technical scheme, when the three-axis motion control software training platform is used, the rotating drive gear drives the two arc-shaped racks meshing with it to move, so that the two arc-shaped racks drive the inclined arm into a rotating shaft The axis rotates, and the object is clamped and moved by the oblique arm, so as to realize the trajectory display of the three-axis linear motion, making the three-axis motion more intuitive to observe and easy to understand.
与现有技术相比,本实用新型的有益效果是:该当三轴运动控制软件实训平台,能够实现三轴运动,并且通过夹持件,通过夹持物体,使学生更加直观的观察三轴运动,便于理解三轴运动,具体内容如下:Compared with the prior art, the beneficial effect of the utility model is: it should be used as a three-axis motion control software training platform, which can realize three-axis motion, and through the clamping parts, by clamping objects, students can observe the three-axis motion more intuitively. Movement, it is easy to understand the three-axis movement, the specific content is as follows:
1、设置有夹持件,当三轴运动控制软件实训平台使用时,旋转电机带动旋转螺杆转动,滑动块沿旋转螺杆的长度方向进行移动,带动移动块移动,夹持电机带动驱动齿轮转动,带动两个与其啮合的弧形齿条移动,从而使两个弧形齿条带动斜臂进一转动轴为轴心进行转动,通过斜臂将物品夹持起来,进行移动,从而实现三轴直线运动的轨迹展示,使得三轴运动观察起来更加直观,便于理解;1. There is a clamping part. When the three-axis motion control software training platform is used, the rotating motor drives the rotating screw to rotate, the sliding block moves along the length direction of the rotating screw, drives the moving block to move, and the clamping motor drives the driving gear to rotate. , drive two arc-shaped racks meshing with it to move, so that the two arc-shaped racks drive the oblique arm into a rotating shaft for rotation, and the object is clamped and moved by the oblique arm, thereby realizing the three-axis The trajectory display of linear motion makes the observation of three-axis motion more intuitive and easy to understand;
2、设置有移动件、升降件和夹持件,当三轴运动控制软件实训平台使用时,驱动电机带动两个同步轴转动,同步轴带动移动螺杆转动,能够使两个移动螺杆同步转动,使套设在其上的升降件进行X轴直线运动,升降电机带动转动辊转动,使主动伞齿随之转动,带动与其啮合的从动伞齿转动,使两个升降螺杆转动,套设在其上的升降架进行Y轴直线运动,旋转电机带动旋转螺杆转动,滑动块沿旋转螺杆的长度方向进行移动,带动移动块移动,进行Z轴直线移动。2. There are moving parts, lifting parts and clamping parts. When the three-axis motion control software training platform is used, the drive motor drives the two synchronous shafts to rotate, and the synchronous shaft drives the moving screw to rotate, so that the two moving screws can rotate synchronously. , so that the lifting piece set on it moves linearly on the X axis, the lifting motor drives the rotating roller to rotate, so that the active bevel gear rotates accordingly, and drives the driven bevel gear meshed with it to rotate, so that the two lifting screws rotate, and the set The lifting frame on it performs Y-axis linear motion, the rotating motor drives the rotating screw to rotate, the sliding block moves along the length direction of the rotating screw, drives the moving block to move, and performs Z-axis linear movement.
附图说明Description of drawings
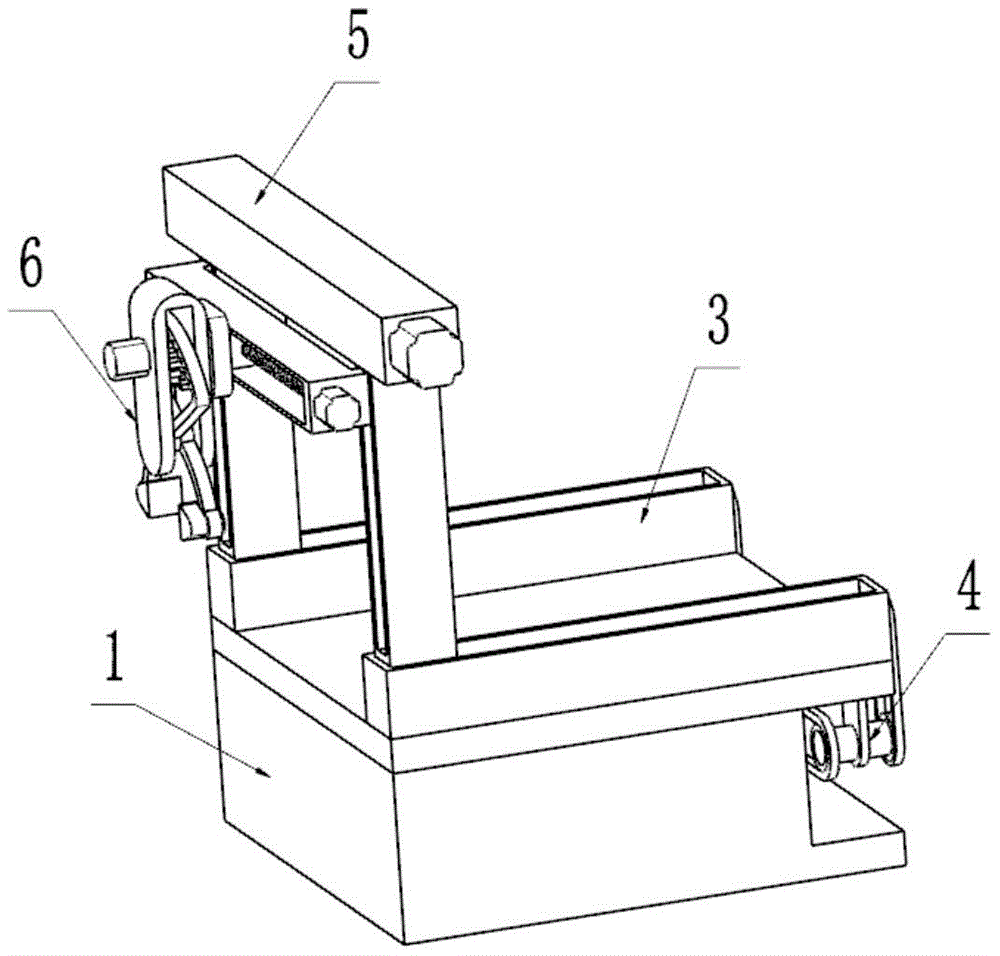
图1为本实用新型立体结构示意图;Fig. 1 is a schematic diagram of the three-dimensional structure of the utility model;
图2为本实用新型移动件立体结构示意图;Fig. 2 is a schematic diagram of the three-dimensional structure of the moving part of the present invention;
图3为本实用新型升降件立体结构示意图;Fig. 3 is a schematic diagram of the three-dimensional structure of the lifting member of the present invention;
图4为图3中A处放大立体结构示意图;Fig. 4 is a schematic diagram of an enlarged three-dimensional structure at A in Fig. 3;
图5为本实用新型夹持件立体结构示意图;Fig. 5 is a schematic diagram of the three-dimensional structure of the clamping part of the present invention;
图6为本实用新型驱动齿轮立体结构示意图。Fig. 6 is a schematic diagram of the three-dimensional structure of the driving gear of the present invention.
图中:1、机架;2、驱动电机;3、滑动壳;4、移动件;41、移动螺杆;42、同步轴;5、升降件;51、安装辊;52、横架;53、升降螺杆;54、转动辊;55、从动伞齿;56、主动伞齿;57、升降电机;6、夹持件;61、升降架;62、旋转螺杆;63、滑动块;64、移动块;65、驱动齿轮;66、转动轴;67、夹持电机;68、旋转电机;69、斜臂;610、弧形齿条。In the figure: 1. frame; 2. driving motor; 3. sliding shell; 4. moving parts; 41. moving screw; 42. synchronous shaft; 5. lifting parts; 51. installation roller; 52. horizontal frame; Lifting screw; 54, rotating roller; 55, driven bevel gear; 56, driving bevel gear; 57, lifting motor; 65, driving gear; 66, rotating shaft; 67, clamping motor; 68, rotating motor; 69, oblique arm; 610, arc rack.
具体实施方式detailed description
下面将结合本实用新型实施例中的附图,对本实用新型实施例中的技术方案进行清楚、完整地描述,显然,所描述的实施例仅仅是本实用新型一部分实施例,而不是全部的实施例。基于本实用新型中的实施例,本领域普通技术人员在没有做出创造性劳动前提下所获得的所有其他实施例,都属于本实用新型保护的范围。The technical solutions in the embodiments of the present invention will be clearly and completely described below in conjunction with the accompanying drawings in the embodiments of the present invention. Obviously, the described embodiments are only part of the embodiments of the present invention, not all of them. example. Based on the embodiments of the present utility model, all other embodiments obtained by persons of ordinary skill in the art without making creative efforts belong to the scope of protection of the present utility model.
请参阅图1-6,本实用新型提供一种技术方案:一种三轴运动控制软件实训平台,包括机架1,机架1的侧壁为开口状,机架1的内顶壁上安装有驱动电机2,机架1的顶部设有两个间隔设置的滑动壳3;Please refer to Figures 1-6, the utility model provides a technical solution: a three-axis motion control software training platform, including a
还包括:移动件4,设有两个,两个移动件4位于驱动电机2的两侧,且每个移动件4均与一个滑动壳3转动连接;升降件5,架设在机架1的上方,且升降件5底部的两端分别套设在两个移动件4上;夹持件6,套设在升降件5上,且夹持件6位于机架1的上方。It also includes: two moving
每个移动件4均包括移动螺杆41,移动螺杆41水平位于一个滑动壳3内,且移动螺杆41的一端与滑动壳3的一内侧壁转动连接,移动螺杆41的另一端贯穿滑动壳3的另一内侧壁并延伸出去,机架1的内顶壁上转动设有同步轴42,且同步轴42与移动螺杆41的另一端传动连接,驱动电机2的输出端与两个同步轴42传动连接,升降件5包括安装辊51,安装辊51设有两个,两个安装辊51间隔竖直位于机架1的顶部,两个安装辊51的底端分别套设在两个移动螺杆41上,两个安装辊51的顶部水平设有横架52,每个安装辊51内均转动设有升降螺杆53,每个升降螺杆53的顶端均贯穿一个安装辊51并延伸出去,横架52内水平转动设有转动辊54,且转动辊54位于两个升降螺杆53的上方,每个升降螺杆53的顶端均设有从动伞齿55,转动辊54上间隔套设有两个主动伞齿56,且每个主动伞齿56均与一个从动伞齿55相啮合,横架52的侧壁上安装有升降电机57,且升降电机57的输出端贯穿横架52与转动辊54固定连接,夹持件6包括升降架61,升降架61套设在两个升降螺杆53上,且升降架61内转动设有旋转螺杆62,旋转螺杆62上套设有滑动块63,且滑动块63与升降架61滑动连接,滑动块63上安装有移动块64,且移动块64呈冂字形结构设置,移动块64内设有驱动齿轮65,且驱动齿轮65为双层结构,驱动齿轮65的下段直径大于驱动齿轮65上段的直径,移动块64内设有与其转动连接的转动轴66,移动块64的侧壁上安装有输出端与驱动齿轮65固定连接的夹持电机67,升降架61上安装有输出端与旋转螺杆62固定连接的旋转电机68,转动轴66上套设有两个间隔设置的斜臂69,且两个斜臂69相贴合,每个斜臂69的顶端均设有与驱动齿轮65相啮合的弧形齿条610,且两个弧形齿条610分别位于驱动齿轮65的上方与下方,如图1-6所示,当三轴运动控制软件实训平台使用时,驱动电机2带动两个同步轴42转动,同步轴42带动移动螺杆41转动,能够使两个移动螺杆41同步转动,使套设在其上的升降件5进行X轴直线运动,升降电机57带动转动辊54转动,使主动伞齿56随之转动,带动与其啮合的从动伞齿55转动,使两个升降螺杆53转动,套设在其上的升降架61进行Y轴直线运动,旋转电机68带动旋转螺杆62转动,滑动块63沿旋转螺杆62的长度方向进行移动,带动移动块64移动,进行Z轴直线移动,夹持电机67带动驱动齿轮65转动,带动两个与其啮合的弧形齿条610移动,从而使两个弧形齿条610带动斜臂69进一转动轴66为轴心进行转动,通过斜臂69将物品夹持起来,进行移动,从而实现三轴直线运动的轨迹展示,使得三轴运动观察起来更加直观,便于理解。Each moving
工作原理:当三轴运动控制软件实训平台使用时,驱动电机2带动两个同步轴42转动,同步轴42带动移动螺杆41转动,能够使两个移动螺杆41同步转动,升降电机57带动转动辊54转动,使主动伞齿56随之转动,带动与其啮合的从动伞齿55转动,使两个升降螺杆53转动,升降架61移动,旋转电机68带动旋转螺杆62转动,滑动块63沿旋转螺杆62的长度方向进行移动,带动移动块64移动,夹持电机67带动驱动齿轮65转动,带动两个与其啮合的弧形齿条610移动,从而使两个弧形齿条610带动斜臂69进一转动轴66为轴心进行转动,通过斜臂69将物品夹持起来,进行移动,从而实现三轴直线运动的轨迹展示。Working principle: When the three-axis motion control software training platform is used, the
本说明书中未作详细描述的内容属于本领域专业技术人员公知的现有技术。The content not described in detail in this specification belongs to the prior art known to those skilled in the art.
尽管参照前述实施例对本实用新型进行了详细的说明,对于本领域的技术人员来说,其依然可以对前述各实施例所记载的技术方案进行修改,或者对其中部分技术特征进行等同替换,凡在本实用新型的精神和原则之内,所作的任何修改、等同替换、改进等,均应包含在本实用新型的保护范围之内。Although the utility model has been described in detail with reference to the aforementioned embodiments, those skilled in the art can modify the technical solutions described in the aforementioned embodiments, or perform equivalent replacements for some of the technical features. Within the spirit and principle of the utility model, any modification, equivalent replacement, improvement, etc., should be included in the protection scope of the utility model.
Claims (6)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202222222003.2U CN218100477U (en) | 2022-08-23 | 2022-08-23 | Triaxial motion control software training platform |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202222222003.2U CN218100477U (en) | 2022-08-23 | 2022-08-23 | Triaxial motion control software training platform |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN218100477U true CN218100477U (en) | 2022-12-20 |
Family
ID=84448203
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202222222003.2U Expired - Fee Related CN218100477U (en) | 2022-08-23 | 2022-08-23 | Triaxial motion control software training platform |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN218100477U (en) |
-
2022
- 2022-08-23 CN CN202222222003.2U patent/CN218100477U/en not_active Expired - Fee Related
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN109615943B (en) | A remote control teaching robot | |
| CN208425810U (en) | A kind of visual communication planar design professional teaching displaying device | |
| CN211429616U (en) | Static electricity eliminating device for electromechanical equipment capable of completely eliminating static electricity | |
| CN208895414U (en) | A kind of welding robot | |
| CN213487587U (en) | Interactive remote teaching platform | |
| CN105904481B (en) | A wrist of a six-axis industrial robot | |
| CN219213152U (en) | Height-adjustable mobile robot | |
| CN214201123U (en) | Artificial xenon lamp aging box | |
| CN202040942U (en) | Lifting device of air conditioner panel and air conditioner with the same | |
| CN207441456U (en) | A kind of low-voltage current mutual inductor | |
| CN204429527U (en) | Tank cabinet frame automatic spray apparatus | |
| CN215848163U (en) | Mill uses multi-functional robotic arm | |
| CN204262223U (en) | Punch press intelligence loading and unloading manipulator | |
| CN221850194U (en) | A two-axis single-side single-arm single-section manipulator | |
| CN208361483U (en) | A kind of more efficient air shaft device | |
| CN215391135U (en) | Two-shaft platform for decontamination robot | |
| CN222584143U (en) | Rotary cigarette display machine | |
| CN223504827U (en) | Rotating device for magic wheel | |
| CN219075681U (en) | Multi-shaft reciprocating mechanism and multi-shaft manipulator | |
| CN219972513U (en) | Swing type hanging tool | |
| CN219842521U (en) | General relay parameter tester | |
| CN221872002U (en) | Micro-motion structure of robot | |
| CN216422615U (en) | Robot vision guiding device | |
| CN218720021U (en) | Triaxial scanning device | |
| CN223160948U (en) | A food delivery service robot |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20221220 |
|
| CF01 | Termination of patent right due to non-payment of annual fee |