CN211919799U - A battery transfer robot - Google Patents
A battery transfer robot Download PDFInfo
- Publication number
- CN211919799U CN211919799U CN202020170360.7U CN202020170360U CN211919799U CN 211919799 U CN211919799 U CN 211919799U CN 202020170360 U CN202020170360 U CN 202020170360U CN 211919799 U CN211919799 U CN 211919799U
- Authority
- CN
- China
- Prior art keywords
- clamping
- laminate
- transfer robot
- cell transfer
- connecting plate
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 230000007246 mechanism Effects 0.000 claims abstract description 54
- 239000011120 plywood Substances 0.000 claims description 4
- 230000013011 mating Effects 0.000 claims 4
- 230000032258 transport Effects 0.000 abstract description 4
- 230000004656 cell transport Effects 0.000 abstract 2
- 238000000034 method Methods 0.000 description 9
- 238000001514 detection method Methods 0.000 description 5
- 238000010586 diagram Methods 0.000 description 5
- 230000000694 effects Effects 0.000 description 3
- 238000004519 manufacturing process Methods 0.000 description 3
- 239000000463 material Substances 0.000 description 2
- 238000004891 communication Methods 0.000 description 1
- 238000007665 sagging Methods 0.000 description 1
- 230000007704 transition Effects 0.000 description 1
- 238000004804 winding Methods 0.000 description 1
Images


Landscapes
- Manipulator (AREA)
Abstract
本实用新型公开了一种电芯转运机器人,该电芯转运机器人包括机械臂本体、夹持机构、推动件和配合件,夹持机构可活动地设在机械臂本体的执行端,夹持机构用于夹持层板,推动件连接在执行端上,执行端能够带动推动件止抵在层板的侧壁上,配合件连接在夹持机构上,配合件用于与层板配合,执行端能够带动配合件将层板从缓存柜内拉出。该电芯转运机器人既能够将层板从缓存柜中稳定取出,也能够将层板稳定地放入缓存柜中,提升了层板转运效率。
The utility model discloses a battery cell transport robot, which includes a mechanical arm body, a clamping mechanism, a pusher and a matching member. The clamping mechanism can be movably arranged at the execution end of the mechanical arm body, the clamping mechanism is used to clamp the layer plate, the pusher is connected to the execution end, the execution end can drive the pusher to stop on the side wall of the layer plate, the matching member is connected to the clamping mechanism, the matching member is used to cooperate with the layer plate, and the execution end can drive the matching member to pull the layer plate out of the cache cabinet. The battery cell transport robot can not only stably take out the layer plate from the cache cabinet, but also stably put the layer plate into the cache cabinet, thereby improving the efficiency of the layer plate transport.
Description
技术领域technical field
本实用新型涉及电池生产运输技术领域,尤其涉及一种电芯转运机器人。The utility model relates to the technical field of battery production and transportation, in particular to a battery cell transfer robot.
背景技术Background technique
在电池生产的过程中,层板通常是放置在缓存柜当中的。现有技术中将层板从缓存柜中取出以及将层板放入缓存柜中需要两个不同的机械臂完成。这样既降低了层板转运效率,在实际使用过程中容易出现两个机械臂相互干扰的现象。During cell production, laminates are usually placed in buffer cabinets. In the prior art, two different manipulators are required to remove the laminate from the cache cabinet and to put the laminate into the cache cabinet. This not only reduces the transport efficiency of the laminates, but also tends to cause the two robotic arms to interfere with each other during actual use.
实用新型内容Utility model content
本实用新型的目的在于提出一种电芯转运机器人,该电芯转运机器人既能够将层板从缓存柜中稳定取出,也能够将层板稳定地放入缓存柜中,提升了层板转运效率。The purpose of this utility model is to propose a cell transfer robot, which can not only stably take out the laminates from the cache cabinet, but also stably put the laminates into the cache cabinet, thereby improving the laminate transfer efficiency .
为实现上述技术效果,本实用新型实施例的电芯转运机器人的技术方案如下:In order to realize the above-mentioned technical effect, the technical scheme of the battery cell transfer robot according to the embodiment of the present invention is as follows:
本实用新型公开了一种电芯转运机器人,包括:机械臂本体;夹持机构,所述夹持机构可活动地设在所述机械臂本体的执行端上,所述夹持机构用于夹持层板;推动件,所述推动件连接在所述执行端上,所述执行端能够带动所述推动件止抵在所述层板的侧壁上;配合件,所述配合件连接在所述夹持机构上,所述配合件用于与所述层板配合,所述执行端能够带动所述配合件将所述层板从缓存柜内拉出。The utility model discloses a battery transfer robot, comprising: a mechanical arm body; a clamping mechanism, wherein the clamping mechanism is movably arranged on the execution end of the mechanical arm body, and the clamping mechanism is used for clamping holding the layer board; a pusher, the pusher is connected to the execution end, and the execution end can drive the pusher to stop on the side wall of the layer plate; a matching piece, the matching piece is connected to the On the clamping mechanism, the matching piece is used to cooperate with the layer board, and the execution end can drive the matching piece to pull the layer board out of the cache cabinet.
在一些实施例中,所述电芯转运机器人还包括连接板,所述连接板连接在所述执行端上,所述夹持机构为两个,两个所述夹持机构可滑动地设在所述连接板上,两个所述夹持机构能够朝向靠近或者远离彼此的方向运动。In some embodiments, the battery cell transfer robot further includes a connecting plate, the connecting plate is connected to the execution end, the number of the clamping mechanisms is two, and the two clamping mechanisms are slidably provided on On the connecting plate, the two clamping mechanisms can move toward or away from each other.
在一些具体的实施例中,每个所述夹持机构均包括:安装板,所述安装板可滑动地设在所述连接板上;第一驱动件,所述第一驱动件与所述安装板相连以驱动所述安装板滑动;夹持组件,所述夹持组件设在所述安装板上,所述夹持组件用于夹持所述层板。In some specific embodiments, each of the clamping mechanisms includes: a mounting plate, the mounting plate is slidably provided on the connecting plate; a first driving member, the first driving member and the The mounting plates are connected to drive the mounting plates to slide; a clamping assembly is provided on the mounting plate, and the clamping assembly is used for clamping the layer plate.
在一些更具体的实施例中,所述夹持组件包括;夹板,所述夹板为两个,两个所述夹板沿上下方向间隔设置;第二驱动件,所述第二驱动件与至少一个所述夹板相配合,所述第二驱动件用于驱动所述夹板运动以使两个所述夹板之间的距离增大或者减小。In some more specific embodiments, the clamping assembly includes: two clamping plates, the two clamping plates are spaced apart along the up-down direction; a second driving member, the second driving member is connected to at least one The clamping plates are matched, and the second driving member is used to drive the clamping plates to move so as to increase or decrease the distance between the two clamping plates.
在一些可选的实施例中,至少一个所述夹板与所述层板的接触面为齿形面。In some optional embodiments, the contact surface of at least one of the splints and the laminate is a toothed surface.
在一些可选的实施例中,所述连接板上设有沿其长度方向延伸设置的滑轨,所述安装板上设有与所述滑轨配合的滑块。In some optional embodiments, the connecting plate is provided with a sliding rail extending along its length direction, and the mounting plate is provided with a sliding block matched with the sliding rail.
在一些可选的实施例中,所述配合件包括:连接部,所述连接板的一端与其中一个所述夹板相连,所述连接部的长度大于所述夹板的长度;配合部,所述配合部连接在所述连接部的另一端,所述配合部能够与所述层板配合。In some optional embodiments, the matching piece includes: a connecting part, one end of the connecting plate is connected to one of the clamping plates, the length of the connecting part is greater than the length of the clamping plate; the matching part, the The matching portion is connected to the other end of the connecting portion, and the matching portion can be matched with the laminate.
在一些可选的实施例中,所述电芯转运机器人还包括:缓冲件,所述缓冲件设在所述连接板上,且所述缓冲件与所述推动件分别位于所述连接板的相对设置的两个侧壁上;压力传感器,所述压力传感器的一端与所述执行端相连,另一端与所述缓冲件相连。In some optional embodiments, the battery cell transfer robot further includes: a buffer member, the buffer member is provided on the connecting plate, and the buffer member and the pushing member are respectively located on the connecting plate. On the two opposite side walls; a pressure sensor, one end of the pressure sensor is connected with the execution end, and the other end is connected with the buffer member.
在一些可选的实施例中,所述电芯转运机器人还包括位置检测件,所述位置检测件设在所述连接板上,所述位置检测件用于检测所述层板的位置。In some optional embodiments, the cell transfer robot further includes a position detection member, the position detection member is provided on the connecting plate, and the position detection member is used to detect the position of the layer board.
在一些可选的实施例中,所述电芯转运机器人还包括走线转轴,所述走线转轴连接在所述机械臂本体的电源线与外部电源之间。In some optional embodiments, the battery cell transfer robot further includes a wire routing shaft, and the wire routing shaft is connected between the power cable of the robotic arm body and an external power source.
本实用新型实施例的电芯转运机器人,由于具有夹持层板的夹持机构,推动层板的推动件以及能够在与层板配合的配合件,实现了既能将层板从缓存柜中取出,又能将层板放入缓存柜的功能,提升了层板转运的效率,降低了层板转运成本。The cell transfer robot according to the embodiment of the present invention has a clamping mechanism for clamping the laminate, a pusher for pushing the laminate, and a fitting that can cooperate with the laminate, so that both the laminate can be removed from the buffer cabinet. The function of taking out and putting the laminate in the cache cabinet improves the efficiency of the transfer of the laminate and reduces the cost of the transfer of the laminate.
本实用新型的附加方面和优点将在下面的描述中部分给出,部分将从下面的描述中变得明显,或通过本实用新型的实践了解到。Additional aspects and advantages of the invention will be set forth, in part, from the following description, and in part will be apparent from the following description, or learned by practice of the invention.
附图说明Description of drawings
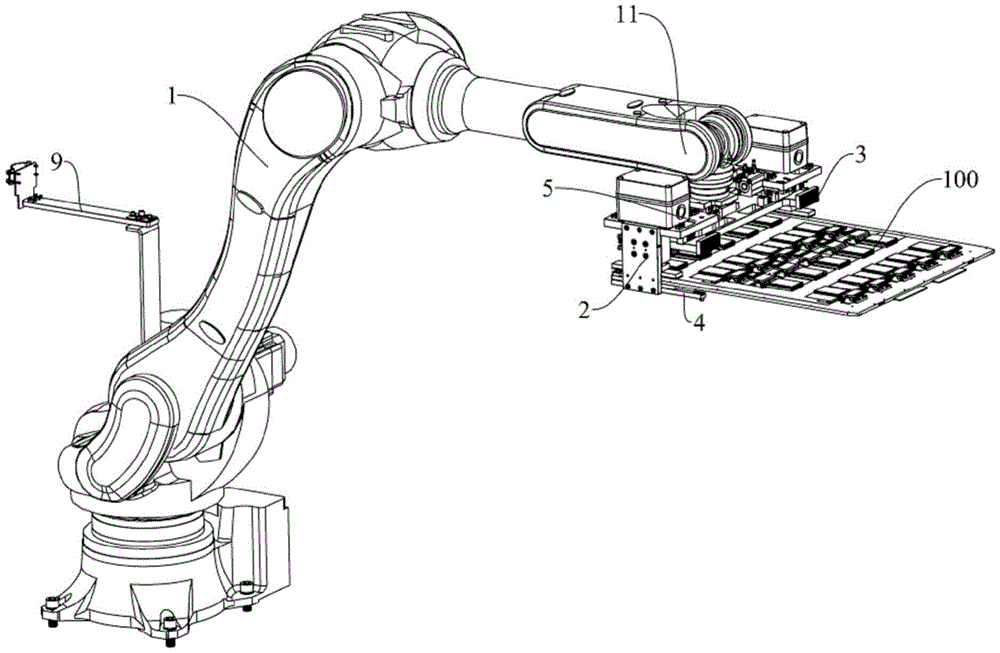
图1是本实用新型实施例的电芯转运机器人与层板的配合结构示意图。FIG. 1 is a schematic diagram of the cooperation structure of a cell transfer robot and a laminate according to an embodiment of the present invention.
图2是本实用新型实施例的电芯转运机器人的局部结构示意图。FIG. 2 is a partial structural schematic diagram of a battery cell transfer robot according to an embodiment of the present invention.
图3是图2的局部结构示意图。FIG. 3 is a schematic diagram of a partial structure of FIG. 2 .
图4是本实用新型实施例的电芯转运机器人的另一个局部结构示意图。FIG. 4 is another partial structural schematic diagram of the battery cell transfer robot according to the embodiment of the present invention.
图5是缓存柜的结构示意图。FIG. 5 is a schematic diagram of the structure of the cache cabinet.
附图标记:Reference number:
1、机械臂本体;11、执行端;1. Robot body; 11. Execution end;
2、夹持机构;21、安装板;211、滑块;22、第一驱动件;23、夹持组件;231、夹板;232、第二驱动件;2. Clamping mechanism; 21, Mounting plate; 211, Slider; 22, First driving part; 23, Clamping assembly; 231, Plywood; 232, Second driving part;
3、推动件;3. Push parts;
4、配合件;41、连接部;42、配合部;4. Matching parts; 41. Connecting part; 42. Matching part;
5、连接板;51、滑轨;5. Connecting plate; 51. Slide rail;
6、缓冲件;7、压力传感器;8、位置检测件;9、走线转轴;100、层板;101、配合孔;200、缓存柜。6. Buffer part; 7. Pressure sensor; 8. Position detection part; 9. Wiring shaft; 100, Laminate; 101, Matching hole; 200, Cache cabinet.
具体实施方式Detailed ways
为使本实用新型解决的技术问题、采用的技术方案和达到的技术效果更加清楚,下面结合附图并通过具体实施方式来进一步说明本实用新型的技术方案。In order to make the technical problems solved by the present invention, the technical solutions adopted and the technical effects achieved more clearly, the technical solutions of the present invention are further described below with reference to the accompanying drawings and through specific embodiments.
在本实用新型的描述中,需要理解的是,术语“中心”、“纵向”、“横向”、“长度”、“宽度”、“厚度”、“上”、“下”、“前”、“后”、“左”、“右”、“竖直”、“水平”、“顶”、“底”、“内”、“外”、“顺时针”、“逆时针”、“轴向”、“径向”、“周向”等指示的方位或位置关系为基于附图所示的方位或位置关系,仅是为了便于描述本实用新型和简化描述,而不是指示或暗示所指的装置或元件必须具有特定的方位、以特定的方位构造和操作,因此不能理解为对本实用新型的限制。In the description of the present invention, it should be understood that the terms "center", "longitudinal", "lateral", "length", "width", "thickness", "upper", "lower", "front", "Back", "Left", "Right", "Vertical", "Horizontal", "Top", "Bottom", "Inner", "Outer", "Clockwise", "Counterclockwise", "Axial" ", "radial", "circumferential" and other indicated orientations or positional relationships are based on the orientations or positional relationships shown in the accompanying drawings, and are only for the convenience of describing the present invention and simplifying the description, rather than indicating or implying the indicated A device or element must have a specific orientation, be constructed and operate in a specific orientation, and therefore should not be construed as a limitation of the present invention.
此外,限定有“第一”、“第二”的特征可以明示或者隐含地包括一个或者更多个该特征,用于区别描述特征,无顺序之分,无轻重之分。在本实用新型的描述中,除非另有说明,“多个”的含义是两个或两个以上。In addition, the features defined with "first" and "second" may explicitly or implicitly include one or more of the features, which are used to distinguish and describe the features, regardless of order or importance. In the description of the present invention, unless otherwise specified, "plurality" means two or more.
在本实用新型的描述中,需要说明的是,除非另有明确的规定和限定,术语“安装”、“相连”、“连接”应做广义理解,例如,可以是固定连接,也可以是可拆卸连接,或一体地连接;可以是机械连接,也可以是电连接;可以是直接相连,也可以通过中间媒介间接相连,可以是两个元件内部的连通。对于本领域的普通技术人员而言,可以具体情况理解上述术语在本实用新型中的具体含义。In the description of the present invention, it should be noted that, unless otherwise expressly specified and limited, the terms "installed", "connected" and "connected" should be understood in a broad sense, for example, it may be a fixed connection or a connectable connection. Detachable connection, or integral connection; may be mechanical connection or electrical connection; may be direct connection, or indirect connection through an intermediate medium, or internal communication between two components. For those of ordinary skill in the art, the specific meanings of the above terms in the present invention can be understood in specific situations.
下面参考图1-图4描述本实用新型实施例的电芯转运机器人的具体结构。The specific structure of the battery cell transfer robot according to the embodiment of the present invention will be described below with reference to FIGS. 1 to 4 .
如图1-图4所示,本实用新型实施例的电芯转运机器人包括机械臂本体1、夹持机构2、推动件3和配合件4,夹持机构2可活动地设在机械臂本体1的执行端11上,夹持机构2用于夹持层板100,推动件3连接在执行端11上,执行端11能够带动推动件3止抵在层板100的侧壁上,配合件4连接在夹持机构2上,配合件4用于与层板100配合,执行端11能够带动配合件4将层板100从缓存柜200内拉出。As shown in FIGS. 1 to 4 , the battery cell transfer robot according to the embodiment of the present invention includes a manipulator body 1, a
可以理解的是,在实际使用过程中,本实施例的电芯转运机器人将层板100放回缓存柜200的过程为,夹持机构2夹持层板100,夹持机构2在机械臂本体1的驱动下朝向靠近缓存柜200的方向运动;当层板100的一部分被缓存柜200内的支撑结构支撑时,夹持机构2松开层板100,然后机械臂本体1继续运动使得推动件3止抵在层板100的侧壁上;当推动件3止抵在层板100的侧壁上后,机械臂本体1继续运动以带动推动件3将层板100缓缓推入层板100存储柜中。由此,本实施例的电芯转运机器人即可实现将层板100放入缓存柜200的功能。It can be understood that, in the actual use process, the process of placing the
与此同时,本实施例的电芯转运机器人将层板100从缓存柜200的取出过程为:机械臂本体1开始运动并且使得配合件4与层板100配合;机械臂本体1继续运动使得层板100在配合件4的带动离开缓存柜200;当层板100的一部分脱离缓存柜200时,机械臂本体1停止运动,配合件4脱离层板100且夹持机构2将层板100脱离缓存柜200的部分稳定夹持;当夹持机构2夹持层板100时,机械臂本体1继续运动从而使得层板100在夹持机构2的带动下离开缓存柜200。由此,本实施例的电芯转运机器人即可实现将层板100从缓存柜200中取出的功能。At the same time, the process of removing the
本实用新型实施例的电芯转运机器人,由于具有夹持层板100的夹持机构2,推动层板100的推动件3以及能够在与层板100配合的配合件4,实现了既能将层板100从缓存柜200中取出,又能将层板100放入缓存柜200的功能,提升了层板100转运的效率,降低了层板100转运成本。The cell transfer robot according to the embodiment of the present invention has the
在一些实施例中,如图2所示,电芯转运机器人还包括连接板5,连接板5连接在执行端11上,夹持机构2为两个,两个夹持机构2可滑动地设在连接板5上,两个夹持机构2能够朝向靠近或者远离彼此的方向运动。In some embodiments, as shown in FIG. 2 , the battery cell transfer robot further includes a connecting
可以理解的是,在电池生产的过程中,由于电池的种类不同,层板100的尺寸也各不相同,在本实施例中,两个夹持机构2均可滑动地设在连接板5上,这样在实际使用时,可以针对不同尺寸的层板100调节两个夹持机构2之间的距离,使得本实施例的电芯转运机器人能够兼容各种长度或者宽度尺寸的层板100,从而扩大了本实施例的电芯转运机器人的适用范围,提升了用户使用满意度。It can be understood that, in the process of battery production, due to the different types of batteries, the dimensions of the
此外,夹持机构2形成为间隔开设置的两个,这样两个夹持机构2既能够分别夹持层板100的一个侧边,保证了夹持机构2能够稳定地夹持层板100,从而避免了在取出或者放入层板100的过程中,层板100从电芯转运机器人上跌落的现象发生。当然,在实际使用过程中,夹持机构2的个数可以根据层板100的尺寸设置为三个或者更多个。In addition, the clamping
在一些具体的实施例中,如图2所示,每个夹持机构2均包括安装板21、第一驱动件22及夹持组件23,安装板21可滑动地设在连接板5上,第一驱动件22与安装板21相连以驱动安装板21滑动,夹持组件23设在安装板21上,夹持组件23用于夹持层板100。可以理解的是,采用可滑动地设在连接板5上的安装板21作为夹持组件23与连接板5之间的过渡连接件,一方面确保了夹持组件23能够稳定地相对连接板5滑动,从而较为方便实现了两个夹持组件23之间的间距的调整,另一方面保证了夹持组件23的稳定性,避免了由于夹持组件23晃动导致的层板100损坏或者跌落的现象发生。这里需要补充说明的是,在本实施例中,第一驱动件22可以是气缸、电动推杆、电机驱动滚珠丝杠等任意直线驱动结构,在此不对第一驱动件22的具体类型做出限定,第一驱动件22的类型可以根据实际需要选择。此外,在本实用新型的其他实施例中,第一驱动件22也可以直接与夹持组件23相连以驱动夹持组件23相对连接板5活动。当然,在有的实施例中,夹持组件23的调整可以是手动调整而非自动调整。In some specific embodiments, as shown in FIG. 2 , each
在一些更具体的实施例中,如图3所示,夹持组件23包括夹板231和第二驱动件232,夹板231为两个,两个夹板231沿上下方向间隔设置,第二驱动件232与至少一个夹板231相配合,第二驱动件232用于驱动夹板231运动以使两个夹板231之间的距离增大或者减小。可以理解的是,由于第二驱动件232能够驱动夹板231运动以使两个夹板231之间的距离增大或者减小,一方面保证夹持组件23能够稳定地夹持层板100,从而避免层板100跌落的现象发生,另一方面针对不同的电池,层板100的厚度可能存在偏差,两个夹板231之间的厚度可调整能够使得本实施例的夹持组件23兼容多种厚度的层板100,从而使得整个电芯转运机器人能够兼容多种厚度的层板100。In some more specific embodiments, as shown in FIG. 3 , the clamping
与此同时,在本实施例中,两个夹板231的相对运动方式可以有多种,例如,在有的实施例中,两个夹板231连接在同一个第二驱动件232上,此时整个夹持组件23形成为一个手指气缸;又例如,在有的实施例中,两个夹板231分别连接在两个第二驱动件232上,当需要调整间距或者夹紧层板100时,两个第二驱动件232分别驱动两个夹板231运动;再例如,在有的实施例中,第二驱动件232与两个夹板231中的一个相连,当需要调整间距或者夹紧层板100时第二驱动件232驱动一个夹板231运动即可。由此,在实际使用中,两个夹板231的相对运动方式可以选择上述描述中的任何一种。At the same time, in this embodiment, the relative movement modes of the two clamping
在一些可选的实施例中,至少一个夹板231与层板100的接触面为齿形面。可以理解的是,夹板231与层板100的接触面为齿形面,一方面能够增加层板100与夹板231之间的摩擦力,从而确保夹持组件23能够稳定地夹紧层板100,另一方面齿形面与层板100的接触面积相对较小,能够降低夹板231损坏层板100的可能。当然,在本实用新型的其他实施例中,夹板231与层板100的接触面可以根据实际需要选择平面、锯齿面、斜面等任何一种或者几种,并不限于本实施例的齿形面。In some optional embodiments, the contact surface of at least one
在一些可选的实施例中,如图3-图4所示,连接板5上设有沿其长度方向延伸设置的滑轨51,安装板21上设有与滑轨51配合的滑块211。可以理解的是,滑轨51与滑块211的配合能够限定安装板21的滑动方向,从而避免安装板21歪斜导致层板100卡死或者层板100损坏的现象。当然,为了限制安装板21的滑动方向,还可以设置滑槽配合凸块的结构,并不限于本实施例的滑轨51配合滑块211的结构。In some optional embodiments, as shown in FIGS. 3 to 4 , the connecting
在一些可选的实施例中,如图3所示,配合件4包括连接部41和配合部42,连接板5的一端与其中一个夹板231相连,连接部41的长度大于夹板231的长度,配合部42连接在连接部41的另一端,配合部42能够与层板100配合。可以理解的是,由于连接部41的一端与夹板231相连,且连接部41的长度大于夹板231的长度,这样较好地避免了在配合部42与层板100配合时,夹板231与层板100发生碰撞的现象,从而降低了层板100的废品率。当然,在本实用新型的其他实施例中,配合件4可以形成为吸嘴等其他能够与层板100相配合的结构。In some optional embodiments, as shown in FIG. 3 , the fitting 4 includes a connecting
这里需要补充说明的是,在本实用新型的其他实施例中,夹持机构2可以形成为一个手指气缸,手指气缸的两个夹持板分别止抵在层板100的两相对设置的侧壁上从而实现对层板100的夹持。也就是说,在本实用新型的其他实施例中,夹持机构2的结构并不限于上述描述,还可以是其他能够实现夹持的机构。It should be supplemented here that in other embodiments of the present invention, the
在一些可选的实施例中,如图4所示,电芯转运机器人还包括缓冲件6和压力传感器7,缓冲件6设在连接板5上,且缓冲件6与推动件3分别位于连接板5的相对设置的两个侧壁上,压力传感器7的一端与执行端11相连,另一端与缓冲件6相连。可以理解的是,在本实施例的电芯转运机器人将层板100放入缓存柜200的过程,当层板100的远离推动件3的一端止抵在层板100柜的侧壁上时,此时如果机械臂本体1的执行端11继续运动并且带动推动件3推动层板100就有可能造成挤压层板100从而导致层板100损坏的现象发生。在本实施例中,电芯转运机器人还包括缓冲件6和压力传感器7,在层板100被放入缓存柜200的过程中,缓冲件6和压力传感器7能够起到缓冲以及测量层板100受到的压力大小的作用,从而较好地避免将层板100放入缓存柜200的过程中损坏层板100的现象In some optional embodiments, as shown in FIG. 4 , the battery cell transfer robot further includes a buffer member 6 and a pressure sensor 7 , the buffer member 6 is provided on the connecting
这里需要说明的额外说明的是,在本实施例的缓冲件6可以是弹簧、橡胶垫等弹性件,具体可以根据实际需要选择。此外,压力传感的型号、种类以及量程均可以根据实际需要选择,在此不做赘述。It should be noted here that the buffer member 6 in this embodiment may be an elastic member such as a spring and a rubber pad, which may be selected according to actual needs. In addition, the model, type and range of the pressure sensor can be selected according to actual needs, which will not be repeated here.
在一些可选的实施例中,如图4所示,电芯转运机器人还包括位置检测件8,位置检测件8设在连接板5上,位置检测件8用于检测层板100的位置。可以理解的是,当从缓存柜200从取出层板100时,当位置检测件8检测到层板100的侧壁时,夹持机构2再将层板100夹持,这样能够较好地保证夹持机构2对层板100的稳定夹持,从而确保了层板100的稳定性,避免了取出层板100的过程中层板100跌落损坏的现象发生。这里需要额外说明的是,位置检测件8可以根据实际需要选择接近开关,光电开关或者其他位置检测件8,在此不对位置检测件8的具体类型以及控制逻辑做出限定。In some optional embodiments, as shown in FIG. 4 , the cell transfer robot further includes a
在一些可选的实施例中,如图1所示,电芯转运机器人还包括走线转轴9,走线转轴9连接在机械臂本体1的电源线与外部电源之间。可以理解的是,走线转轴9用于连接电线从而实现机械臂本体1偏转时,电源线以及电线在走线转轴9的控制下一起随着电芯转运机器人转动,从而避免现有技术走线自然下垂导致缠绕在电芯转运机器人上的不良现象发生。In some optional embodiments, as shown in FIG. 1 , the cell transfer robot further includes a wire routing shaft 9 , and the wire routing shaft 9 is connected between the power cable of the manipulator body 1 and an external power source. It can be understood that when the wire routing shaft 9 is used to connect the wires so as to realize the deflection of the manipulator body 1, the power cord and the wires rotate together with the battery transfer robot under the control of the wire routing shaft 9, thereby avoiding the wire routing in the prior art. The natural sagging leads to the occurrence of undesirable phenomena wrapped around the cell transfer robot.
实施例:Example:
下面参考图1-图4描述本实用新型一个具体实施例的电芯转运机器人的具体结构。The specific structure of a cell transfer robot according to a specific embodiment of the present invention will be described below with reference to FIGS. 1 to 4 .
如图1-图4所示,本实施例的电芯转运机器人包括机械臂本体1、夹持机构2、推动件3、配合件4、连接板5、缓冲件6、压力传感器7、位置检测件8及走线转轴9。As shown in FIGS. 1-4 , the cell transfer robot of this embodiment includes a manipulator body 1, a
夹持机构2为两个,夹持机构2为两个,两个夹持机构2可滑动地设在连接板5上,两个夹持机构2能够朝向靠近或者远离彼此的方向运动。每个夹持机构2均包括安装板21、第一驱动件22及夹持组件23,连接板5上设有沿其长度方向延伸设置的滑轨51,安装板21上设有与滑轨51配合的滑块211,第一驱动件22与安装板21相连以驱动安装板21滑动,夹持组件23设在安装板21上,夹持组件23用于夹持层板100。夹持组件23包括两个夹板231和第二驱动件232,夹板231为两个,两个夹板231沿上下方向间隔设置,第二驱动件232与位于上侧的一个夹板231相配合,第二驱动件232用于驱动夹板231运动以使两个夹板231之间的距离增大或者减小。配合件4包括连接部41和配合部42,连接板5的一端与位于下侧的一个夹板231相连,连接部41的长度大于夹板231的长度,配合部42连接在连接部41的另一端,配合部42能够与层板100配合。夹持机构2可活动地设在机械臂本体1的执行端11,夹持机构2用于夹持层板100,推动件3连接在执行端11上,执行端11能够带动推动件3止抵在层板100的侧壁上,配合件4连接在夹持机构2上,配合件4用于与层板100配合,执行端11能够带动配合件4将层板100从缓存柜200内拉出。缓冲件6设在连接板5上,且缓冲件6与推动件3分别位于连接板5的相对设置的两个侧壁上,压力传感器7的一端与执行端11相连,另一端与缓冲件6相连。位置检测件8设在连接板5上,位置检测件8用于检测层板100的位置。走线转轴9连接在机械臂本体1的电源线与外部电源之间。There are two clamping
本实施例的电芯转运机器人的工作原理为:The working principle of the cell transfer robot of the present embodiment is:
将层板100放入缓存柜200时:机械臂本体1将层板100转运至缓存柜200所在位置,并使得层板100部分伸入放入缓存柜200后,第二驱动件232驱动上方的夹板231朝向远离下方的夹板231的方向运动,夹持组件23打开释放层板100,由推动件3控制实现对层板100的推送到位;When the
将层板100取出缓存柜200时:机械臂本体1移送至缓存柜200所在位置,控制配合部42插入层板100上的配合孔101(如图5所示)后,机械臂本体1后移,拉出该层板100,第二驱动件232控制夹板231朝向靠近另一个夹板231的方向运动从而实现对的夹紧,将层板100从缓存柜200中取出,并移送至其他位置。When the
本实施例的电芯转运机器人具有以下优点:The cell transfer robot of this embodiment has the following advantages:
第一:既能将层板100从缓存柜200中取出,又能将层板100放入缓存柜200内,降低了层板100转运成本,提升了层板100的转运效率;First: the laminate 100 can be taken out from the
第二:两个夹持组件23之间的间距可调,每个夹持组件23的两个夹紧板之间的间距可调,实现了对各种长度、宽度以及厚度尺寸电芯的兼容,提升了电芯层片转运机器人的适用范围;Second: the distance between the two clamping
第三:增设的走线转轴9能够较好地避免走线缠绕碰撞等现象发生,保证了整个电芯转运机器人的可靠性。Third: the additionally installed wire routing shaft 9 can better avoid the occurrence of wire winding collision and other phenomena, and ensure the reliability of the entire battery cell transfer robot.
在本说明书的描述中,参考术语“有些实施例”、“其他实施例”、等的描述意指结合该实施例或示例描述的具体特征、结构、材料或者特点包含于本实用新型的至少一个实施例或示例中。在本说明书中,对上述术语的示意性表述不一定指的是相同的实施例或示例。而且,描述的具体特征、结构、材料或者特点可以在任何的一个或多个实施例或示例中以合适的方式结合。In the description of this specification, description with reference to the terms "some embodiments", "other embodiments", etc. means that a particular feature, structure, material or characteristic described in connection with the embodiment or example is included in at least one of the present invention examples or examples. In this specification, schematic representations of the above terms do not necessarily refer to the same embodiment or example. Furthermore, the particular features, structures, materials or characteristics described may be combined in any suitable manner in any one or more embodiments or examples.
以上内容仅为本实用新型的较佳实施例,对于本领域的普通技术人员,依据本实用新型的思想,在具体实施方式及应用范围上均会有改变之处,本说明书内容不应理解为对本实用新型的限制。The above content is only a preferred embodiment of the present invention. For those of ordinary skill in the art, according to the idea of the present invention, there will be changes in the specific implementation and application scope, and the content of this description should not be construed as Limitations of the present invention.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202020170360.7U CN211919799U (en) | 2020-02-14 | 2020-02-14 | A battery transfer robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202020170360.7U CN211919799U (en) | 2020-02-14 | 2020-02-14 | A battery transfer robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211919799U true CN211919799U (en) | 2020-11-13 |
Family
ID=73351983
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202020170360.7U Active CN211919799U (en) | 2020-02-14 | 2020-02-14 | A battery transfer robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211919799U (en) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112830233A (en) * | 2020-12-30 | 2021-05-25 | 珠海格力智能装备有限公司 | Anchor clamps and window machine air conditioner production line |
| CN113734787A (en) * | 2021-09-18 | 2021-12-03 | 浙江杭可科技股份有限公司 | Six transport manipulators of battery ageing board |
| CN115415192A (en) * | 2022-08-25 | 2022-12-02 | 深圳市海目星激光智能装备股份有限公司 | A battery buffer device and method |
-
2020
- 2020-02-14 CN CN202020170360.7U patent/CN211919799U/en active Active
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112830233A (en) * | 2020-12-30 | 2021-05-25 | 珠海格力智能装备有限公司 | Anchor clamps and window machine air conditioner production line |
| CN113734787A (en) * | 2021-09-18 | 2021-12-03 | 浙江杭可科技股份有限公司 | Six transport manipulators of battery ageing board |
| CN115415192A (en) * | 2022-08-25 | 2022-12-02 | 深圳市海目星激光智能装备股份有限公司 | A battery buffer device and method |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110739481B (en) | Shell equipment | |
| WO2023241489A1 (en) | Material picking device | |
| CN111762562A (en) | A kind of multifunctional battery handling manipulator and battery handling method | |
| CN113911754A (en) | Mechanical automation pile up neatly machinery hand | |
| CN111525175A (en) | Cell transfer mechanism and cell pressing device | |
| CN113146234A (en) | Motor capacitor assembly machine | |
| CN107381023B (en) | Multidirectional material transfer device | |
| CN211182392U (en) | Shell device is gone into to electricity core | |
| CN107225591A (en) | A kind of three workpiece grip the flexible mechanical arm carried and pick and place material simultaneously | |
| CN206852187U (en) | Hung on a kind of slider of zipper fastener is automatic standby | |
| CN215093692U (en) | Clamping device | |
| WO2024259593A1 (en) | Transferring device, battery production line and feeding method for battery cells | |
| CN115626459A (en) | A linkage loading type buckle robot | |
| CN116331619A (en) | Robot assembly system for bookmark production line and method of use thereof | |
| CN221160396U (en) | Turnover clamping jaw for processing energy storage battery | |
| CN211362304U (en) | Six claw interlock anchor clamps of power battery | |
| CN211350843U (en) | Shell entering equipment | |
| CN112828871B (en) | Multi-station logistics manipulator device | |
| CN107738266B (en) | Handle grabbing device for automatic pressing mobile phone | |
| CN111170005A (en) | Loading and unloading device | |
| JP7101280B1 (en) | Goods transfer robot | |
| JP2017030090A (en) | Robot hand, information processor manufacturing device, and information processor manufacturing method | |
| CN209850946U (en) | Clamping device and transfer robot | |
| CN106853615B (en) | An automatic locking mechanism of a battery fixture and a locking system using it | |
| CN214816433U (en) | Motor capacitor assembling device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |