CN211518505U - High accuracy 3D printer - Google Patents
High accuracy 3D printer Download PDFInfo
- Publication number
- CN211518505U CN211518505U CN201922345823.9U CN201922345823U CN211518505U CN 211518505 U CN211518505 U CN 211518505U CN 201922345823 U CN201922345823 U CN 201922345823U CN 211518505 U CN211518505 U CN 211518505U
- Authority
- CN
- China
- Prior art keywords
- scraper
- plate
- screw
- precision
- optical
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Abstract
本实用新型涉及一种高精度3D打印机,其包括机架、光机、光机调节机构、安装板、盛料机构、编码器、Z轴模组、打印平台以及刮刀高度调节机构;其中,所述光机通过光机调节机构安装于机架上,且光机调节机构能够调整光机位置;所述安装板固定于机架的上方;所述盛料机构安装于安装板上;所述编码器和盛料机构配合;所述Z轴模组连接于机架上,其上安装有打印平台,并能驱动打印平台升降;所述刮刀高度调节机构设置于盛料机构的一侧,其上安装有刮刀,并能驱动刮刀升降而调整刮刀高度。本实用新型的高精度3D打印机具有光机精度可调,自动化程度高且性能稳定等诸多优点。
The utility model relates to a high-precision 3D printer, which comprises a frame, an opto-mechanical, an opto-mechanical adjustment mechanism, a mounting plate, a material holding mechanism, an encoder, a Z-axis module, a printing platform and a scraper height adjustment mechanism; The optical machine is installed on the frame through the optical-mechanical adjustment mechanism, and the optical-mechanical adjustment mechanism can adjust the position of the optical-machine; the installation plate is fixed on the top of the frame; the material holding mechanism is installed on the installation plate; the coding The Z-axis module is connected to the frame, and the printing platform is installed on it, and can drive the printing platform to rise and fall; the scraper height adjustment mechanism is arranged on one side of the feeding mechanism, on which A scraper is installed, and can drive the scraper to rise and fall to adjust the scraper height. The high-precision 3D printer of the utility model has many advantages such as adjustable opto-mechanical precision, high degree of automation and stable performance.
Description
【技术领域】【Technical field】
本实用新型涉及一种打印机,具体涉及一种高精度3D打印机,属于3D打印技术领域。The utility model relates to a printer, in particular to a high-precision 3D printer, which belongs to the technical field of 3D printing.
【背景技术】【Background technique】
3D打印机又称三维打印机,是一种采用累积制造技术(即快速成形技术)的机器,它的原理是把数据和原料放进3D打印机中,机器按照程序把产品一层层造出来。A 3D printer, also known as a three-dimensional printer, is a machine that uses cumulative manufacturing technology (ie, rapid prototyping technology). Its principle is to put data and raw materials into the 3D printer, and the machine builds the product layer by layer according to the program.
现有技术的3D打印机如中华人民共和国实用新型专利申请第201610863393.8号所示。然而,上述打印机在实际使用过程中往往存在以下缺陷:The prior art 3D printer is shown in the People's Republic of China Utility Model Patent Application No. 201610863393.8. However, the above printers often have the following defects in the actual use process:
1.该打印机的光机在人工调焦后位置是固定的,不能根据需要调整光机的投影范围,因此其精度是不可调整的,从而大大降低了打印机的打印精度。1. The position of the optical machine of the printer is fixed after manual focusing, and the projection range of the optical machine cannot be adjusted as needed, so its accuracy cannot be adjusted, which greatly reduces the printing accuracy of the printer.
2.该打印机的树脂盒由齿轮传动,但其转动角度无法精确计量和控制,具有一定的局限性。2. The resin box of this printer is driven by gears, but its rotation angle cannot be precisely measured and controlled, which has certain limitations.
3.该打印机的刮刀高度只能手动调节,其调节麻烦,调节精度低。3. The height of the scraper of this printer can only be adjusted manually, which is troublesome to adjust and has low adjustment accuracy.
因此,为解决上述技术问题,确有必要提供一种创新的高精度3D打印机,以克服现有技术中的所述缺陷。Therefore, in order to solve the above technical problems, it is indeed necessary to provide an innovative high-precision 3D printer to overcome the defects in the prior art.
【实用新型内容】【Content of utility model】
为解决上述技术问题,本实用新型的目的在于一种光机精度可调,自动化程度高且性能稳定的高精度3D打印机,In order to solve the above-mentioned technical problems, the purpose of this utility model is a high-precision 3D printer with adjustable optomechanical precision, high degree of automation and stable performance,
为实现上述目的,本实用新型采取的技术方案为:一种高精度3D打印机,其包括机架、光机、光机调节机构、安装板、盛料机构、编码器、Z轴模组、打印平台以及刮刀高度调节机构;其中,所述光机通过光机调节机构安装于机架上,且光机调节机构能够调整光机位置;所述安装板固定于机架的上方;所述盛料机构安装于安装板上;所述编码器和盛料机构配合;所述Z轴模组连接于机架上,其上安装有打印平台,并能驱动打印平台升降;所述刮刀高度调节机构设置于盛料机构的一侧,其上安装有刮刀,并能驱动刮刀升降而调整刮刀高度。In order to achieve the above purpose, the technical solution adopted by the present invention is as follows: a high-precision 3D printer, which includes a frame, an opto-mechanical, an opto-mechanical adjustment mechanism, a mounting plate, a material holding mechanism, an encoder, a Z-axis module, a printing Platform and scraper height adjustment mechanism; wherein, the optical machine is installed on the frame through the optical machine adjustment mechanism, and the optical machine adjustment mechanism can adjust the position of the optical machine; the mounting plate is fixed on the top of the frame; The mechanism is installed on the mounting plate; the encoder cooperates with the material holding mechanism; the Z-axis module is connected to the frame, and the printing platform is installed on it, and can drive the printing platform to rise and fall; the scraper height adjustment mechanism is set A scraper is installed on one side of the material holding mechanism, and the scraper can be driven to rise and fall to adjust the height of the scraper.
本实用新型的高精度3D打印机进一步设置为:所述光机调节机构包括底板、光机粗调座、下调节板、光机调平微分螺母以及上调节板;其中,所述底板水平固定于机架上;所述光机粗调座安装于底板上,其顶部连接至下调节板的底部,并能抵顶下调节板升降;所述光机调平微分螺母安装于下调节板上,其顶部抵顶上调节板并能微调上调节板的位置;所述光机固定于上调节板的顶部。The high-precision 3D printer of the present invention is further configured as follows: the optical-mechanical adjustment mechanism comprises a base plate, an optical-mechanical coarse adjustment seat, a lower adjustment plate, an optical-mechanical leveling differential nut and an upper adjustment plate; wherein, the base plate is horizontally fixed on the on the frame; the optical-mechanical coarse adjustment seat is installed on the bottom plate, the top of which is connected to the bottom of the lower adjustment plate, and can be lifted up and down against the lower adjustment plate; the optical-mechanical leveling differential nut is installed on the lower adjustment plate, Its top abuts the upper adjustment plate and can fine-tune the position of the upper adjustment plate; the optical machine is fixed on the top of the upper adjustment plate.
本实用新型的高精度3D打印机进一步设置为:所述光机粗调座具体为一可升降的光机粗调座,其连接至下调节板的底部中央。The high-precision 3D printer of the present invention is further configured as follows: the optical-mechanical coarse adjustment seat is specifically a liftable optical-mechanical coarse adjustment seat, which is connected to the bottom center of the lower adjustment plate.
本实用新型的高精度3D打印机进一步设置为:所述光机调平微分螺母具体设置有四颗,并设置在下调节板的四角。The high-precision 3D printer of the present utility model is further configured as follows: the opto-mechanical leveling differential nuts are specifically provided with four, and are provided at the four corners of the lower adjusting plate.
本实用新型的高精度3D打印机进一步设置为:所述下调节板上设有锁紧螺栓;所述锁紧螺栓穿出上调节板;所述上调节板能沿锁紧螺栓升降。The high-precision 3D printer of the present invention is further configured as follows: the lower adjusting plate is provided with locking bolts; the locking bolts pass through the upper adjusting plate; and the upper adjusting plate can be lifted and lowered along the locking bolts.
本实用新型的高精度3D打印机进一步设置为:所述盛料机构包括转盘轴承、安装座、树脂盒、驱动电机以及驱动齿轮;其中,所述转盘轴承枢接于安装板上,其外侧设有一圈外齿圈;所述安装座安装于外齿圈上;所述树脂盒和安装座固接;所述驱动电机安装于安装板的底部,其连接并驱动驱动齿轮转动;所述驱动齿轮和外齿圈相啮合,使驱动电机驱动转盘轴承和树脂盒转动。The high-precision 3D printer of the present utility model is further configured as follows: the material holding mechanism includes a turntable bearing, a mounting seat, a resin box, a driving motor and a driving gear; wherein, the turntable bearing is pivotally connected to the mounting plate, and an outer side thereof is provided with a turntable bearing. the outer ring gear; the mounting seat is mounted on the outer ring gear; the resin box and the mounting seat are fixedly connected; the driving motor is mounted on the bottom of the mounting plate, which is connected and drives the driving gear to rotate; the driving gear and The outer ring gear is meshed to make the drive motor drive the turntable bearing and the resin box to rotate.
本实用新型的高精度3D打印机进一步设置为:所述编码器上连接有一从动齿轮,所述从动齿轮和外齿圈相啮合,编码器通过测算从动齿轮转动的角度来得出树脂盒转动的角度。The high-precision 3D printer of the present invention is further configured as follows: the encoder is connected with a driven gear, the driven gear and the outer gear are engaged, and the encoder obtains the rotation of the resin box by measuring the rotation angle of the driven gear Angle.
本实用新型的高精度3D打印机进一步设置为:所述树脂盒底部固定透光玻璃,所述树脂盒及其透光玻璃在编码器控制下转动360°的整数倍。The high-precision 3D printer of the present invention is further configured as follows: a transparent glass is fixed at the bottom of the resin box, and the resin box and the transparent glass are rotated by an integer multiple of 360° under the control of an encoder.
本实用新型的高精度3D打印机进一步设置为:所述Z轴模组包括电机座、丝杆座I、Z轴电机、丝杆I、升降滑块以及打印平台安装座;其中,其中,所述机架的顶部固定有一顶板;所述电机座固定于顶板上;所述丝杆座I固定于电机座的上部;所述Z轴电机安装于电机座上;所述丝杆I竖直设置并枢接于丝杆座上;所述Z轴电机连接并驱动丝杆I转动;所述升降滑块和丝杆I配合,并通过丝杆I转动而驱动升降滑块升降;所述打印平台安装座固持于升降滑块上,其上安装有所述打印平台。The high-precision 3D printer of the present invention is further configured as follows: the Z-axis module includes a motor seat, a screw seat I, a Z-axis motor, a screw I, a lifting slider and a printing platform mounting seat; wherein, the said The top of the frame is fixed with a top plate; the motor base is fixed on the top plate; the screw base I is fixed on the upper part of the motor base; the Z-axis motor is installed on the motor base; the screw rod I is vertically arranged and It is pivotally connected to the screw seat; the Z-axis motor is connected and drives the screw rod I to rotate; the lifting slider is matched with the screw rod I, and the lifting slider is driven to rise and fall by the rotation of the screw rod I; the printing platform is installed The seat is fixed on the lifting slider, on which the printing platform is installed.
本实用新型的高精度3D打印机进一步设置为:所述刮刀高度调节机构包括驱动模块、楔形块、导轨、驱动滑块、刮刀导向轴承、刮刀高度调节柱以及刮刀支架;其中,所述驱动模块安装于顶板上;所述楔形块连接至驱动模块并由驱动模块驱动而移动;所述导轨和楔形块固接,两者联动;所述驱动滑块和导轨配合,并能沿导轨移动,且楔形块能顶升驱动滑块;所述刮刀导向轴承固定于安装板上;所述刮刀高度调节柱底端连接至驱动滑块上,其穿过刮刀导向轴承,顶端连接所述刮刀支架。The high-precision 3D printer of the present invention is further configured as follows: the scraper height adjustment mechanism includes a drive module, a wedge block, a guide rail, a drive slider, a scraper guide bearing, a scraper height adjustment column and a scraper bracket; wherein, the drive module is installed on the top plate; the wedge block is connected to the drive module and is driven by the drive module to move; the guide rail and the wedge block are fixedly connected, and the two are linked together; the drive slider is matched with the guide rail and can move along the guide rail, and the wedge shaped The block can lift the drive slider; the scraper guide bearing is fixed on the mounting plate; the bottom end of the scraper height adjustment column is connected to the drive slider, which passes through the scraper guide bearing, and the top end is connected to the scraper bracket.
本实用新型的高精度3D打印机进一步设置为:所述驱动模块具体包括刮刀升降电机、丝杆座II、丝杆II以及移动滑块;其中,所述丝杆座II固持于顶板上;所述刮刀升降电机安装于丝杆座II的一侧;所述丝杆II呈水平设置,并枢接于丝杆座II上,其连接并由刮刀升降电机驱动而转动;所述移动滑块和丝杆II配合,其能由丝杆II驱动而沿丝杆II移动;所述楔形块连接于移动滑块上。The high-precision 3D printer of the present invention is further configured as follows: the drive module specifically includes a scraper lift motor, a screw base II, a screw II and a moving slider; wherein, the screw base II is fixed on the top plate; the The scraper lift motor is installed on one side of the screw base II; the screw rod II is arranged horizontally and is pivotally connected to the screw base II, which is connected and driven by the scraper lift motor to rotate; the moving slider and the screw The rod II is matched and can be driven by the screw II to move along the screw II; the wedge block is connected to the moving slider.
本实用新型的高精度3D打印机还可设置为:所述丝杆座II上设有一对倒V型导引条;所述移动滑块上设有和导引条相配合的倒V型导槽;所述倒V型导引条对称分布于丝杆II的两侧。The high-precision 3D printer of the present invention can also be configured as follows: the screw seat II is provided with a pair of inverted V-shaped guide bars; the moving slider is provided with inverted V-shaped guide grooves matched with the guide bars ; The inverted V-shaped guide bars are symmetrically distributed on both sides of the screw II.
与现有技术相比,本实用新型具有如下有益效果:Compared with the prior art, the utility model has the following beneficial effects:
1.本实用新型的高精度3D打印机通过光机粗调座和光机调平微分螺母来粗调和微调光机的位置,从而能够对光机进行调焦,进而调整光机的投影范围,大大提高了打印机的打印精度。1. The high-precision 3D printer of the present utility model roughly adjusts and finely adjusts the position of the optomechanical machine through the optomechanical coarse adjustment seat and the optomechanical leveling differential nut, so that the optomechanical focus can be adjusted, and then the projection range of the optomechanical machine can be adjusted, which greatly improves the performance of the optical machine. the printing accuracy of the printer.
2.本实用新型的高精度3D打印机通过设置编码器,当转盘轴承因为异物卡住堵转,导致丢步时,进行立即停止驱动电机,防止损坏树脂盒;同时,其亦能检测到转盘轴承步数有少量的丢步或者多步时进行相应的反馈,让驱动电机进行相应的步数补偿。2. By setting the encoder, the high-precision 3D printer of the present utility model stops the drive motor immediately when the turntable bearing is stuck due to a foreign object and causes the rotor to lose steps to prevent damage to the resin box; at the same time, it can also detect the turntable bearing. When the number of steps has a small amount of lost steps or multiple steps, the corresponding feedback is performed, so that the drive motor can compensate for the corresponding number of steps.
3.本实用新型的高精度3D打印机采用电机驱动刮刀高度调节机构,进而来控制刮刀的高度,使刮刀高度调节方便,自动化程度高;并使刮刀底边与树脂盒底的间距控制精准,使打印层的厚度均匀和精准。3. The high-precision 3D printer of the present utility model adopts a motor-driven scraper height adjustment mechanism to control the height of the scraper, so that the scraper height can be easily adjusted and the degree of automation is high; The thickness of the printed layer is uniform and precise.
【附图说明】【Description of drawings】
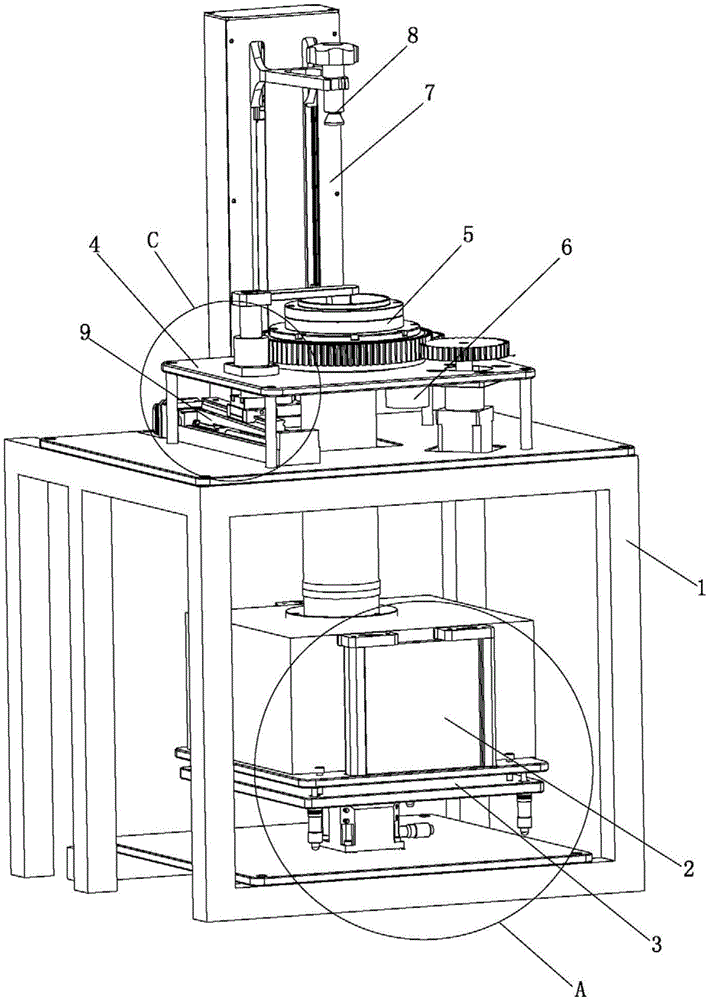
图1是本实用新型的高精度3D打印机的立体图。FIG. 1 is a perspective view of the high-precision 3D printer of the present invention.
图2是本实用新型的高精度3D打印机另一视角的立体图。2 is a perspective view of the high-precision 3D printer of the present invention from another perspective.
图3是图1中A处的局部放大图。FIG. 3 is a partial enlarged view of A in FIG. 1 .
图4是图1中B处的局部放大图。FIG. 4 is a partial enlarged view of B in FIG. 1 .
图5是本实用新型的高精度3D打印机的Z轴模组的结构示意图。5 is a schematic structural diagram of a Z-axis module of the high-precision 3D printer of the present invention.
图6是图1中C处的局部放大图。FIG. 6 is a partial enlarged view of C in FIG. 1 .
图7是本实用新型的盛料机构的剖面图。7 is a cross-sectional view of the material holding mechanism of the present invention.
【具体实施方式】【Detailed ways】
请参阅说明书附图1至附图7所示,本实用新型为一种高精度3D打印机,其由机架1、光机2、光机调节机构3、安装板4、盛料机构5、编码器6、Z轴模组7、打印平台8以及刮刀高度调节机构9等几部分组成。Please refer to the accompanying
其中,所述光机2通过光机调节机构3安装于机架1上,且光机调节机构3能够调整光机2位置。所述光机2为市售高精度光机,故,在此不再赘述。The optomechanical 2 is mounted on the
具体的说,所述光机调节机构3由底板31、光机粗调座32、下调节板33、光机调平微分螺母34以及上调节板35等几部分组成。所述底板31水平固定于机架1上。Specifically, the
所述光机粗调座32安装于底板31上,其顶部连接至下调节板33的底部,并能抵顶下调节板33升降。在本实施方式中,所述光机粗调座32为可升降的光机粗调座,其连接至下调节板33的底部中央。The optical-mechanical
所述光机调平微分螺母34安装于下调节板33上,其顶部抵顶上调节板35并能微调上调节板35的位置。所述光机调平微分螺母34具体设置有四颗,并设置在下调节板4的四角,其能稳定的支撑上调节板35。The optical-mechanical leveling
所述光机2固定于上调节板35的顶部,其随上调节板35的位置调整而相应调整。The
进一步的,所述下调节板33上设有锁紧螺栓36;所述锁紧螺栓36穿出上调节板35;所述上调节板35能沿锁紧螺栓36升降。Further,
所述光机调节机构3的设计原理如下:当需要调整光机2的位置时,先调节光机粗调座32,使光机粗调座32依次驱动下调节板33、光机调平微分螺母34、上调节板35,通过上调节板35联动光机2,进而初步调整光机2的位置;再调节光机调平微分螺母34,使光机调平微分螺母34驱动上调节板35,使上调节板35微调,通过上调节板35联动光机2,进而精确调整光机2的位置,最后通过锁紧螺栓36把上调节板35固定锁紧。The design principle of the optical-
所述光机调节机构3通过光机粗调座32和光机调平微分螺母34来粗调和微调光机2的位置,从而能够对光机2焦距进行调整,以获得清晰的投影图像,大大提高了打印机的打印精度。The
进一步的,所述安装板4水平固定于机架1的上方。所述盛料机构5安装于安装板4上。Further, the mounting plate 4 is horizontally fixed above the
具体的说,所述盛料机构5由转盘轴承51、安装座52、树脂盒53、驱动电机54以及驱动齿轮55等几部分组成。其中,所述转盘轴承51枢接于安装板4上,其外侧设有一圈外齿圈56,该外齿圈56能转动;所述转盘轴承51的内侧固定。Specifically, the
所述安装座52安装于外齿圈56上,其随外齿圈56的旋转而旋转。所述树脂盒53和安装座52固接,两者联动。所述树脂盒53的底部固定有透光玻璃58。The mounting
所述驱动电机54安装于安装板4的底部,其连接并驱动驱动齿轮55转动。所述驱动齿轮55和外齿圈56相啮合,使驱动电机54驱动转盘轴承51和树脂盒53转动。The
所述编码器6和上述盛料机构5配合。具体的说,所述编码器6上连接有一从动齿轮61,所述从动齿轮61和盛料机构5的外齿圈56相啮合。当转盘轴承51因为异物卡住堵转,导致丢步时,该编码器6能进行立即停止驱动电机54,防止损坏树脂盒53;同时,其亦能检测到转盘轴承51步数有少量的丢步或者多步时进行相应的反馈,让驱动电机54进行相应的步数补偿。The
当驱动电机54驱动转盘轴承51的外齿圈56转动后,外齿圈56亦联动从动齿轮61,编码器6通过测算从动齿轮61转动的角度来得出盛料机构5的树脂盒53转动的角度,从而使打印层的厚度控制精准。When the
同时,所述树脂盒53转动角度通过编码器6控制,使树脂盒53转动都是360°的整数倍,进而使树脂盒53底部的透光玻璃58在每次打印时的位置恒定,从而能减少因为透光玻璃58平面度误差导致的打印误差。At the same time, the rotation angle of the
所述Z轴模组7连接于机架1上,其上安装有打印平台8,并能驱动打印平台8升降。具体的说,该Z轴模组7由电机座71、丝杆座I72、Z轴电机73、丝杆I74、升降滑块75以及打印平台安装座76等几部分组成。The Z-
其中,所述机架1的顶部固定有一顶板11;所述电机座71固定于顶板11上。所述丝杆座I72固定于电机座71的上部。所述Z轴电机73安装于电机座71上。Wherein, a
所述丝杆I74竖直设置并枢接于丝杆座72上;所述Z轴电机73连接并驱动丝杆I74转动。The screw rod I74 is vertically arranged and pivoted on the
所述升降滑块75和丝杆I74配合,并通过丝杆I74转动而驱动升降滑块75升降。所述打印平台安装座76固持于升降滑块75上,其上安装有所述打印平台8。The lifting
所述Z轴模组7工作时,Z轴电机73驱动丝杆I74,丝杆I74转动带动升降滑块75升降,升降滑块75联动打印平台安装座76,打印平台安装座76再驱动其上的打印平台8升降。When the Z-
再进一步的,所述刮刀高度调节机构9设置于盛料机构5的一侧,其上安装有刮刀10,并能驱动刮刀10升降而调整刮刀高度。在本实施方式中,所述刮刀为现有技术,故,在此不再赘述。Still further, the scraper height adjustment mechanism 9 is arranged on one side of the
所述刮刀高度调节机构9由驱动模块91、楔形块92、导轨93、驱动滑块94、刮刀导向轴承95、刮刀高度调节柱96以及刮刀支架97等几部分组成。The scraper height adjustment mechanism 9 is composed of a
其中,所述驱动模块91安装于顶板11上。在本实施方式中,所述驱动模块91采用丝杠驱动模块,具体由刮刀升降电机911、丝杆座II912、丝杆II913以及移动滑块914等几部分组成。所述丝杆座II912固持于顶板11上。所述刮刀升降电机911安装于丝杆座II912的一侧。所述丝杆II913呈水平设置,并枢接于丝杆座II912上,其连接并由刮刀升降电机911驱动而转动。所述移动滑块914和丝杆II913配合,其能由丝杆II913驱动而沿丝杆II913移动。Wherein, the driving
所述丝杆座II912上设有一对倒V型导引条98;所述倒V型导引条98对称分布于丝杆II913的两侧。所述移动滑块914上设有和导引条98相配合的倒V型导槽99。通过导引条98和倒V型导槽99的配合,从而能够引导移动滑块914,避免移动滑块914偏转。The screw seat II912 is provided with a pair of inverted V-shaped guide bars 98; the inverted V-shaped guide bars 98 are symmetrically distributed on both sides of the screw rod II913. The moving
所述楔形块92连接至驱动模块91并由驱动模块91驱动而移动。具体的说,所述楔形块92连接于驱动模块91的移动滑块914上。The
所述导轨93和楔形块92固接,两者联动。所述驱动滑块94和导轨93配合,并能沿导轨93移动,且楔形块92能顶升驱动滑块94。The
所述刮刀导向轴承95固定于安装板4上。所述刮刀高度调节柱96底端连接至驱动滑块94上,其穿过刮刀导向轴承95,顶端连接所述刮刀支架97。The scraper guide bearing 95 is fixed on the mounting plate 4 . The bottom end of the scraper
所述刮刀高度调节机构9的工作原理如下:刮刀升降电机911驱动丝杆II913转动,丝杆II913带动移动滑块914移动;再通过移动滑块914联动固定于其上的楔形块92和导轨93移动。由于楔形块92呈倾斜设置,因而导轨93亦呈倾斜设置。当导轨93倾斜移动时,驱动滑块94能沿导轨93移动,同时,驱动滑块94能顶升或者下拉刮刀高度调节柱96,刮刀高度调节柱96联动刮刀支架97,刮刀支架97再驱动刮刀10升降。The working principle of the scraper height adjustment mechanism 9 is as follows: the
所述刮刀高度调节机构9采用刮刀升降电机911驱动,进而来控制刮刀的高度,使刮刀高度调节方便,自动化程度高;并使刮刀底边与树脂盒53底的间距控制精准,使打印层的厚度均匀和精准。The scraper height adjustment mechanism 9 is driven by the
以上的具体实施方式仅为本创作的较佳实施例,并不用以限制本创作,凡在本创作的精神及原则之内所做的任何修改、等同替换、改进等,均应包含在本创作的保护范围之内。The above specific embodiments are only preferred embodiments of this creation, and are not intended to limit this creation. Any modifications, equivalent replacements, improvements, etc. made within the spirit and principles of this creation shall be included in this creation. within the scope of protection.
Claims (12)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922345823.9U CN211518505U (en) | 2019-12-24 | 2019-12-24 | High accuracy 3D printer |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201922345823.9U CN211518505U (en) | 2019-12-24 | 2019-12-24 | High accuracy 3D printer |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN211518505U true CN211518505U (en) | 2020-09-18 |
Family
ID=72446669
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201922345823.9U Active CN211518505U (en) | 2019-12-24 | 2019-12-24 | High accuracy 3D printer |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN211518505U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111055495A (en) * | 2019-12-24 | 2020-04-24 | 浙江迅实科技有限公司 | High accuracy 3D printer |
| CN114474728A (en) * | 2022-01-26 | 2022-05-13 | 中国农业大学 | High-resolution printing nozzle transmission control mechanism, device, system and method |
-
2019
- 2019-12-24 CN CN201922345823.9U patent/CN211518505U/en active Active
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111055495A (en) * | 2019-12-24 | 2020-04-24 | 浙江迅实科技有限公司 | High accuracy 3D printer |
| CN114474728A (en) * | 2022-01-26 | 2022-05-13 | 中国农业大学 | High-resolution printing nozzle transmission control mechanism, device, system and method |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN204799942U (en) | Laser sintering 3D printer | |
| CN110757786B (en) | A 3D printer online laser leveling detection method | |
| CN111055495B (en) | A high-precision 3D printer | |
| CN108081611B (en) | Photo-curing three-dimensional printing equipment and printing method | |
| CN219153734U (en) | A sinking 3D printer capable of adjusting the position of the scraper | |
| CN111645321A (en) | Leveling system and method of light curing equipment | |
| CN108943726B (en) | Leveling device and leveling method for desktop type 3D printer | |
| CN206899755U (en) | Increasing material manufacturing device for Stereolithography | |
| CN219988479U (en) | Volumetric light curing 3D printing device | |
| CN110757800A (en) | An industrial sla laser 3D printer | |
| CN214354193U (en) | Projection distance adjustable photocuring printer | |
| CN118458370B (en) | Automatic positioning, picking and conveying device for optical lens mold | |
| CN214354192U (en) | Light curing printer with adjustable projection position | |
| CN206696709U (en) | A kind of precision of powder laying compensation system for quickly shaping device | |
| CN210886230U (en) | But height-adjusting's cladding laser head support | |
| CN218489122U (en) | Double-material-groove photocuring 3D printer | |
| CN116512599B (en) | A photopolymerization micro/nano 3D printing device and method for achieving gradient mechanical structures through grayscale modulation | |
| CN110757798B (en) | Multi-material 3D printer | |
| CN211492852U (en) | An optomechanical adjustment mechanism for a high-precision 3D printer | |
| CN211390155U (en) | Multi-material 3D printer | |
| CN209433180U (en) | A kind of Z axis movement mechanism for write-through exposure machine | |
| CN214164032U (en) | A printer Z-axis platform lifting system formed by light-curing resin | |
| CN210336921U (en) | 3D printer bottom levelling device | |
| CN223934411U (en) | Lifting structure of UV printer beam | |
| CN210759278U (en) | Adjustable platform frame for 3D printer |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |