CN209957836U - Machine tool for laser quenching of die - Google Patents
Machine tool for laser quenching of die Download PDFInfo
- Publication number
- CN209957836U CN209957836U CN201920209485.3U CN201920209485U CN209957836U CN 209957836 U CN209957836 U CN 209957836U CN 201920209485 U CN201920209485 U CN 201920209485U CN 209957836 U CN209957836 U CN 209957836U
- Authority
- CN
- China
- Prior art keywords
- axis
- plate
- gear
- reducer
- rack
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images


Landscapes
- Machine Tool Units (AREA)
Abstract
本实用新型实施例适用于激光加工技术领域,提供了一种用于模具激光淬火的机床,其包括机床底座、X轴组件、Y轴组件、Z轴组件以及用于夹持激光发生器的机械臂,X轴组件安装于机床底座上,Y轴组件安装于X轴组件上,Z轴组件安装于Y轴组件上,机械臂远离激光发生器的一端安装于Z轴组件上,X轴组件驱动Y轴组件沿X轴方向移动,Y轴组件驱动Z轴组件沿Y轴方向移动,并能驱动Z轴组件带动机械臂沿Z轴方向移动,机械臂夹持激光发生器的一端靠近机床底座,并且能绕Z轴旋转。本实用新型实施例可以高效的完成对不同形状、尺寸规格模具的淬火加工,在加工过程中不需要二次装夹且相比于其他的传统设备淬火深度更加均匀,淬火精度更高。
The embodiments of the present utility model are applicable to the technical field of laser processing, and provide a machine tool for laser quenching of molds, which includes a machine tool base, an X-axis assembly, a Y-axis assembly, a Z-axis assembly, and a machine for clamping a laser generator. Arm, the X-axis assembly is installed on the machine base, the Y-axis assembly is installed on the X-axis assembly, the Z-axis assembly is installed on the Y-axis assembly, the end of the robotic arm away from the laser generator is installed on the Z-axis assembly, and the X-axis assembly drives The Y-axis assembly moves along the X-axis direction, the Y-axis assembly drives the Z-axis assembly to move along the Y-axis direction, and can drive the Z-axis assembly to drive the robotic arm to move along the Z-axis direction, and the robotic arm clamps one end of the laser generator close to the machine base. And can rotate around the Z axis. The embodiment of the utility model can efficiently complete the quenching processing of molds of different shapes and sizes, does not require secondary clamping during the processing, and has more uniform quenching depth and higher quenching accuracy than other traditional equipment.
Description
技术领域technical field
本实用新型属于激光加工技术领域,尤其涉及一种用于模具激光淬火的机床。The utility model belongs to the technical field of laser processing, in particular to a machine tool for laser quenching of molds.
背景技术Background technique
目前,市场上大部分模具的淬火工序,普遍采用火焰淬火的方式,由操作人员手持火焰枪对模具上需要淬火的部位进行淬火处理。采用以上这种淬火方式会造成模具淬火部位淬火深度不均匀、淬火精度不能保证、工作人员劳动强度大、生产效率低。现在虽然有部分企业会采用机械臂代替人工操作,这种方法虽然对上述问题能够有所改观,但是由于受机械臂臂展的限制,也只能够完成臂展范围类小型模具的淬火,对于臂展达不到的地方仍然需要二次装夹,操作繁琐。At present, flame quenching is generally adopted in the quenching process of most of the molds on the market. The operator holds a flame gun to quench the parts on the mold that need to be quenched. Using the above quenching method will result in uneven quenching depth of the quenched part of the mold, inability to guarantee the quenching accuracy, high labor intensity of the staff, and low production efficiency. Although some companies will use robotic arms instead of manual operations, this method can improve the above problems, but due to the limitation of the arm span of the robotic arm, it can only complete the quenching of small molds with a span range. Where the exhibition cannot reach, secondary clamping is still required, and the operation is cumbersome.
实用新型内容Utility model content
本实用新型实施例所要解决的技术问题在于提供一种用于模具激光淬火的机床,旨在解决现有技术采用机械臂代替人工操作对模具进行淬火时受机械臂臂展的限制,只能够完成臂展范围类小型模具的淬火,对于臂展达不到的地方仍然需要二次装夹导致淬火深度不均匀、淬火精度不能保证以及生产效率低等问题。The technical problem to be solved by the embodiments of the present utility model is to provide a machine tool for laser quenching of molds, which aims to solve the limitation of the arm span of the robotic arms when quenching the molds by using a robotic arm instead of manual operation in the prior art, which can only complete For the quenching of small molds with arm span range, secondary clamping is still required for places where the arm span cannot be reached, resulting in uneven quenching depth, unguaranteed quenching accuracy, and low production efficiency.
本实用新型实施例是这样实现的,一种用于模具激光淬火的机床包括机床底座、X轴组件、Y轴组件、Z轴组件以及用于夹持激光发生器的机械臂,所述X轴组件安装于所述机床底座上,所述Y轴组件安装于所述X轴组件上,所述Z轴组件安装于所述Y轴组件上,所述机械臂远离激光发生器的的一端安装于所述Z轴组件上,所述X轴组件驱动所述Y轴组件沿X轴方向移动,所述Y轴组件驱动所述Z轴组件沿Y轴方向移动,并能驱动所述Z轴组件带动所述机械臂沿Z轴方向移动,所述机械臂夹持激光发生器的一端靠近所述机床底座,并且能绕Z轴旋转。The embodiments of the present invention are realized in this way, a machine tool for laser quenching of molds includes a machine tool base, an X-axis assembly, a Y-axis assembly, a Z-axis assembly, and a mechanical arm for clamping a laser generator, the X-axis The assembly is installed on the machine base, the Y-axis assembly is installed on the X-axis assembly, the Z-axis assembly is installed on the Y-axis assembly, and the end of the robotic arm away from the laser generator is installed on the On the Z-axis assembly, the X-axis assembly drives the Y-axis assembly to move along the X-axis direction, the Y-axis assembly drives the Z-axis assembly to move along the Y-axis direction, and can drive the Z-axis assembly to drive The robotic arm moves along the Z-axis direction, and one end of the robotic arm clamping the laser generator is close to the machine tool base, and can rotate around the Z-axis.
进一步地,所述机床底座包括主立柱、副立柱、底座连接梁以及地脚调整板,所述主立柱与所述副立柱均安装在所述地脚调整板上,所述主立柱与所述副立柱相互平行设置,所述底座连接梁连接在所述主立柱和所述副立柱之间。Further, the machine tool base includes a main column, an auxiliary column, a base connecting beam and a foot adjustment plate, the main column and the auxiliary column are both installed on the foot adjustment plate, and the main column is connected to the foot adjustment plate. The auxiliary columns are arranged in parallel with each other, and the base connecting beam is connected between the main column and the auxiliary column.
进一步地,所述X轴组件包括X轴第一横梁主体、X轴第二横梁主体、X轴连接梁、X轴第一滑板、X轴第二滑板、第一驱动件、第二驱动件、第一直线导轨、第二直线导轨、第一滑块、第二滑块、第一齿条以及第二齿条,所述X轴连接梁连接所述X轴第一横梁主体和所述X轴第二横梁主体,所述X轴第一横梁主体和所述X轴第二横梁主体均安装在所述机床底座上,并且所述X轴第一横梁主体和所述X轴第二横梁主体相互平行,所述X轴第一横梁主体上安装有所述第一直线导轨和所述第一齿条,所述第一滑块能滑动地安装于所述第一直线导轨上,所述X轴第一滑板安装在所述第一滑块上,所述第一驱动件安装在所述X轴第一滑板上,所述第一驱动件的输出端连接有第一齿轮,所述第一齿轮与所述第一齿条啮合连接,所述第一驱动件驱动所述X轴第一滑板沿所述X轴方向移动;Further, the X-axis assembly includes the X-axis first beam body, the X-axis second beam body, the X-axis connecting beam, the X-axis first sliding plate, the X-axis second sliding plate, the first driving member, the second driving member, a first linear guide rail, a second linear guide rail, a first slider, a second slider, a first rack and a second rack, and the X-axis connecting beam connects the X-axis first beam body and the X-axis The X-axis second beam body, the X-axis first beam body and the X-axis second beam body are both mounted on the machine base, and the X-axis first beam body and the X-axis second beam body are are parallel to each other, the first linear guide rail and the first rack are installed on the X-axis first beam main body, and the first sliding block is slidably installed on the first linear guide rail, so The X-axis first sliding plate is installed on the first slider, the first driving member is installed on the X-axis first sliding plate, the output end of the first driving member is connected with a first gear, the The first gear is meshed with the first rack, and the first driving member drives the X-axis first sliding plate to move along the X-axis direction;
所述X轴第二横梁主体上安装有所述第二直线导轨和所述第二齿条,所述第二滑块能滑动地安装于所述第二直线导轨上,所述X轴第二滑板安装在所述第二滑块上,所述第二驱动件安装在所述X轴第二滑板上,所述第二驱动件的输出端连接有第二齿轮,所述第二齿轮与第二齿条啮合连接,所述第二驱动件驱动所述X轴第二滑板沿所述X轴方向移动;The second linear guide rail and the second rack are installed on the X-axis second beam main body, the second sliding block is slidably installed on the second linear guide rail, and the X-axis second The sliding plate is installed on the second sliding block, the second driving member is installed on the X-axis second sliding plate, the output end of the second driving member is connected with a second gear, and the second gear is connected with the first The two racks are meshed and connected, and the second driving member drives the X-axis second sliding plate to move along the X-axis direction;
所述Y轴组件的两端分别安装于所述X轴第一滑板和所述X轴第二滑板上。Both ends of the Y-axis assembly are respectively mounted on the X-axis first sliding plate and the X-axis second sliding plate.
进一步地,所述X轴组件还包括第一调整板和第二调整板,所述第一驱动件安装在所述第一调整板上,所述第一调整板安装在所述X轴第一滑板上,所述第二驱动件安装在所述第二调整板上,所述第二调整板安装在所述X轴第二滑板上。Further, the X-axis assembly further includes a first adjustment plate and a second adjustment plate, the first drive member is installed on the first adjustment plate, and the first adjustment plate is installed on the X-axis first adjustment plate On the sliding plate, the second driving member is installed on the second adjustment plate, and the second adjustment plate is installed on the X-axis second sliding plate.
进一步地,所述第一调整板与所述第二调整板上均开设有腰形孔,所述X轴第一滑板与所述X轴第二滑板上均开设有连接孔,所述第一调整板与所述X轴第一滑板之间及所述第二调整板与所述X轴第二滑板之间均通过连接件穿过所述腰形孔与所述连接孔固定连接。Further, both the first adjustment plate and the second adjustment plate are provided with waist-shaped holes, the X-axis first slide plate and the X-axis second slide plate are both provided with connection holes, and the first Between the adjustment plate and the X-axis first sliding plate and between the second adjustment plate and the X-axis second sliding plate, connecting pieces pass through the waist-shaped hole and are fixedly connected to the connecting hole.
进一步地,所述第一驱动件包括第一伺服电机和第一减速机,所述第一伺服电机和所述第一减速机传动连接,所述第一减速机与所述第一齿轮传动连接,所述第一减速机安装在所述第一调整板上,所述第二驱动件包括第二伺服电机和第二减速机,所述第二伺服电机与所述第二减速机传动连接,所述第二减速机与所述第二齿轮传动连接,所述第二减速机安装在所述第二调整板上。Further, the first driving member includes a first servo motor and a first reducer, the first servo motor and the first reducer are connected in a drive, and the first reducer is connected with the first gear drive. , the first reducer is mounted on the first adjustment plate, the second driving member includes a second servo motor and a second reducer, the second servo motor is connected to the second reducer in a transmission manner, The second reducer is connected with the second gear, and the second reducer is mounted on the second adjusting plate.
进一步地,所述Y轴组件包括Y轴横梁主体、第三直线导轨、第三滑块、第三齿条、Y轴滑座、第三驱动件以及第四驱动件,所述Y轴横梁主体的两端分别安装于所述X轴第一滑板和所述X轴第二滑板上,所述第三滑块能滑动地安装于所述第三直线导轨上,所述第三直线导轨和所述第三齿条均安装在所述Y轴横梁主体上,所述Y轴滑座安装在所述第三滑块上,所述第三驱动件和所述第四驱动件安装于所述Y轴滑座上,所述第三驱动件的输出端连接有第三齿轮,所述第三齿轮与所述第三齿条啮合连接,所述第三驱动件驱动所述Y轴滑座沿Y轴方向移动,所述Z轴组件沿Z轴方向可滑动地安装于所述Y轴滑座上,所述第四驱动件驱动所述Z轴组件沿Z轴方向移动。Further, the Y-axis assembly includes a Y-axis beam main body, a third linear guide rail, a third sliding block, a third rack, a Y-axis sliding seat, a third driving member and a fourth driving member. The Y-axis beam main body The two ends are respectively installed on the X-axis first slide and the X-axis second slide, the third slide is slidably mounted on the third linear guide, the third linear guide and all The third racks are installed on the main body of the Y-axis beam, the Y-axis sliding seat is installed on the third sliding block, and the third driving member and the fourth driving member are installed on the Y-axis On the shaft slide, the output end of the third driving member is connected with a third gear, the third gear is meshed with the third rack, and the third driving member drives the Y-axis slide along the Y axis. The Z-axis assembly is slidably mounted on the Y-axis sliding seat along the Z-axis direction, and the fourth driving member drives the Z-axis assembly to move along the Z-axis direction.
进一步地,所述Y轴组件还包括第三调整板和第四调整板,所述第三驱动件安装在所述第三调整板上,所述第三调整板安装在所述Y轴滑座上,所述第四驱动件安装在所述第四调整板上,所述第四调整板安装在所述Y轴滑座上。Further, the Y-axis assembly further includes a third adjusting plate and a fourth adjusting plate, the third driving member is mounted on the third adjusting plate, and the third adjusting plate is mounted on the Y-axis sliding seat On the upper side, the fourth driving member is mounted on the fourth adjusting plate, and the fourth adjusting plate is mounted on the Y-axis sliding seat.
进一步地,所述第三驱动件包括第三伺服电机和第三减速机,所述第三伺服电机和所述第三减速机传动连接,所述第三减速机与所述第三齿轮传动连接,所述第三减速机安装在所述第三调整板上,所述第四驱动件包括第四伺服电机和第四减速机,所述第四伺服电机和所述第四减速机传动连接,所述第四驱动件的输出端连接有第四齿轮,所述第四减速机与所述第四齿轮传动连接,所述第四减速机安装在所述第四调整板上。Further, the third driving member includes a third servo motor and a third reducer, the third servo motor and the third reducer are drive-connected, and the third reducer is drive-connected with the third gear , the third reducer is mounted on the third adjustment plate, the fourth driving member includes a fourth servo motor and a fourth reducer, and the fourth servo motor and the fourth reducer are drive-connected, The output end of the fourth driving member is connected with a fourth gear, the fourth reducer is connected with the fourth gear in a driving manner, and the fourth reducer is mounted on the fourth adjusting plate.
进一步地,所述Z轴组件包括Z轴滑枕、连接板、连接座、第四直线导轨、第四滑块以及第四齿条,所述第四滑块安装于所述Y轴滑座上,所述第四直线导轨、所述第四齿条以及所述连接板均安装在所述Z轴滑枕上,所述第四直线导轨能滑动地安装于所述第四滑块上,所述第四齿轮与所述第四齿条啮合连接,所述连接座安装在所述连接板上,所述机械臂包括旋转气缸和用于夹持激光发生器的夹持部,所述旋转气缸安装于所述连接座上,所述旋转气缸的输出端连接所述夹持部。Further, the Z-axis assembly includes a Z-axis ram, a connecting plate, a connecting seat, a fourth linear guide rail, a fourth sliding block and a fourth rack, and the fourth sliding block is mounted on the Y-axis sliding seat , the fourth linear guide rail, the fourth rack and the connecting plate are all installed on the Z-axis ram, the fourth linear guide rail can be slidably installed on the fourth sliding block, the The fourth gear is in meshing connection with the fourth rack, the connecting seat is mounted on the connecting plate, the mechanical arm includes a rotating cylinder and a clamping part for clamping the laser generator, the rotating cylinder is installed On the connecting seat, the output end of the rotating cylinder is connected to the clamping portion.
本实用新型实施例与现有技术相比,有益效果在于:本实用新型提供一种用于模具激光淬火的机床,X轴组件固定在机床底座上,Y轴组件安装于X轴组件上并可沿X轴方向移动,Z轴组件安装于Y轴组件上,机械臂的一端安装于Z轴组件上,Y轴组件驱动Z轴组件沿Y轴方向移动,并能驱动Z轴组件带动机械臂沿Z轴方向移动,机械臂可绕Z轴组件转动,从而能够利用机械臂夹持激光发生器沿X、Y、Z轴方向移动以及绕Z轴旋转来对放置于机床底座中部位置的模具进行大范围淬火加工,以高效的完成对不同形状、尺寸规格模具的淬火加工,在加工过程中不需要二次装夹,相比于其他的传统设备淬火深度更加均匀,淬火精度更高。Compared with the prior art, the embodiment of the present utility model has the beneficial effects that: the present utility model provides a machine tool for laser quenching of molds, the X-axis assembly is fixed on the machine base, the Y-axis assembly is installed on the X-axis assembly and can be Move along the X-axis direction, the Z-axis assembly is installed on the Y-axis assembly, and one end of the robotic arm is installed on the Z-axis assembly, the Y-axis assembly drives the Z-axis assembly to move along the Y-axis direction, and can drive the Z-axis assembly to drive the robotic arm along the Moving in the Z-axis direction, the robot arm can rotate around the Z-axis assembly, so that the robot arm can clamp the laser generator to move along the X, Y, Z-axis directions and rotate around the Z-axis to make large-scale molds placed in the middle of the machine base. The range quenching process can efficiently complete the quenching process of molds of different shapes and sizes, and does not require secondary clamping during the processing. Compared with other traditional equipment, the quenching depth is more uniform and the quenching accuracy is higher.
附图说明Description of drawings
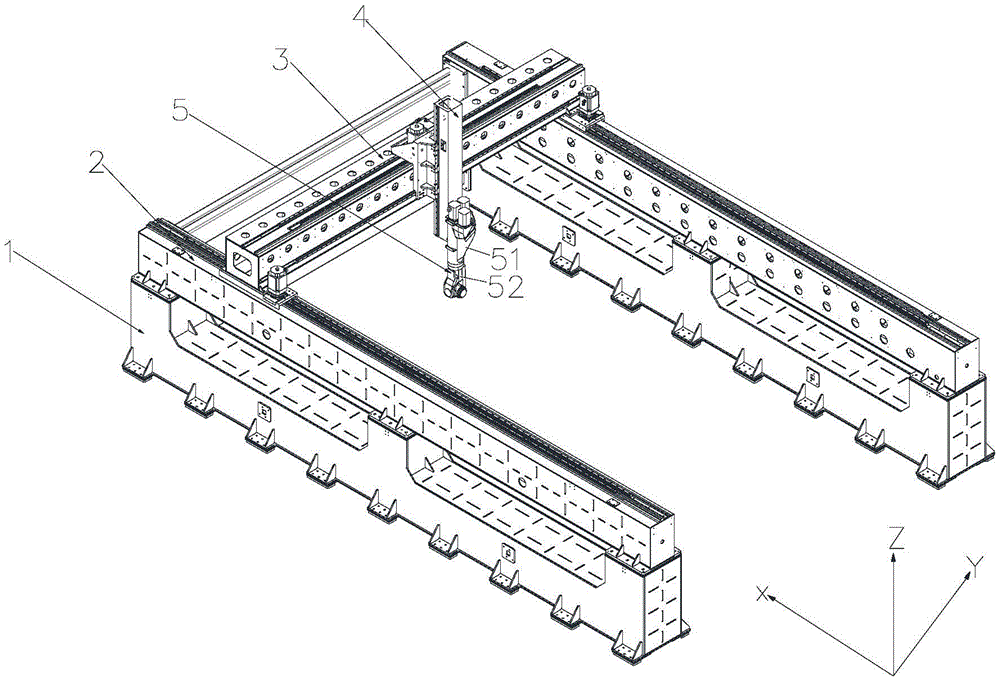
图1是本实用新型提供的一种三维六轴机床的结构示意图;1 is a schematic structural diagram of a three-dimensional six-axis machine tool provided by the present utility model;
图2是图1中机床底座的分解结构示意图;Fig. 2 is the exploded structure schematic diagram of the machine tool base in Fig. 1;
图3是图1中X轴组件的分解结构示意图;Fig. 3 is the exploded structure schematic diagram of X-axis assembly in Fig. 1;
图4是图1中Y轴组件的分解结构示意图;Fig. 4 is the exploded structure schematic diagram of Y-axis assembly in Fig. 1;
图5是图1中Z轴组件的分解结构示意图;Fig. 5 is the exploded structure schematic diagram of Z-axis assembly in Fig. 1;
图6是图3中A区域的放大结构示意图。FIG. 6 is an enlarged schematic view of the structure of the area A in FIG. 3 .
图中:1、机床底座;11、主立柱;12、副立柱;13、底座连接梁;14、地脚调整板;2、X轴组件;21、X轴第一横梁主体;22、X轴第二横梁主体;23、X轴连接梁;24、X轴第一滑板;25、X轴第二滑板;26、第一驱动件;261、第一伺服电机;262、第一减速机;263、第一齿轮;27、第二驱动件;271、第二伺服电机;272、第二减速机;273、第二齿轮;28、第一直线导轨;29、第二直线导轨;210、第一滑块;211、第二滑块;212、第一齿条;213、第二齿条;214、第一调整板;215、第二调整板;216、腰形孔;3、Y轴组件;31、Y轴横梁主体;32、第三直线导轨;33、第三滑块;34、第三齿条;35、Y轴滑座;36、第三驱动件;361、第三伺服电机;362、第三减速机;363、第三齿轮;37、第四驱动件;371、第四伺服电机;372、第四减速机;373、第四齿轮;38、第三调整板;39、第四调整板;4、Z轴组件;41、Z轴滑枕;42、连接板;43、连接座;44、第四直线导轨;45、第四滑块;46、第四齿条;5、机械臂;51、旋转气缸;52、夹持部。In the figure: 1. Machine tool base; 11. Main column; 12. Secondary column; 13. Base connecting beam; 14. Foot adjustment plate; 2. X-axis assembly; 21. Main body of X-axis first beam; 22.
具体实施方式Detailed ways
为了使本实用新型的目的、技术方案及优点更加清楚明白,以下结合附图及实施例,对本实用新型进行进一步详细说明。应当理解,此处所描述的具体实施例仅仅用以解释本实用新型,并不用于限定本实用新型。In order to make the purpose, technical solutions and advantages of the present utility model more clearly understood, the present utility model will be further described in detail below with reference to the accompanying drawings and embodiments. It should be understood that the specific embodiments described herein are only used to explain the present invention, and are not intended to limit the present invention.
如图1至图6所示,是本实用新型提供的一种用于模具激光淬火的机床,该机床包括机床底座1、X轴组件2、Y轴组件3、Z轴组件4以及用于夹持激光发生器的机械臂5,X轴组件2安装于机床底座1上,Y轴组件3安装于X轴组件2上,Z轴组件4安装于Y轴组件3上,机械臂5远离激光发生器的一端安装于Z轴组件4上,X轴组件2驱动Y轴组件3沿X轴方向移动,Y轴组件3驱动Z轴组件4沿Y轴方向移动,并能驱动Z轴组件4带动机械臂5沿Z轴方向移动,机械臂5夹持激光发生器的一端靠近机床底座1,并且能绕Z轴旋转,具体地,机床底座1包括主立柱11、副立柱12、底座连接梁13以及地脚调整板14,主立柱11与副立柱12均通过螺栓安装在地脚调整板14上,主立柱11与副立柱12相互平行设置,通过调节螺栓可以对主立柱11与副立柱12进行调节,使主立柱11与副立柱12处于同一水平面,底座连接梁13通过螺栓连接在主立柱11和副立柱12之间,将主立柱11与副立柱12连接成一整体,保证了机床底座1结构的稳定性;X轴组件2包括X轴第一横梁主体21、X轴第二横梁主体22、X轴连接梁23、X轴第一滑板24、X轴第二滑板25、第一驱动件26、第二驱动件27、第一直线导轨28、第二直线导轨29、第一滑块210、第二滑块211、第一齿条212以及第二齿条213,X轴第一横梁主体21安装在主立柱11上,X轴第二横梁主体22安装在副立柱12上,X轴连接梁23通过螺栓连接X轴第一横梁主体21和X轴第二横梁主体22,将X轴第一横梁主体21与X轴第二横梁主体22连接在一起,有效的提高了X轴组件2的整体刚性及稳定性,X轴第一横梁主体21和X轴第二横梁主体22均安装在机床底座1上,并且X轴第一横梁主体21和X轴第二横梁主体22相互平行,X轴第一横梁主体21上安装有第一直线导轨28和第一齿条212,第一滑块210能滑动地安装于第一直线导轨28上,X轴第一滑板24安装在第一滑块210上,第一驱动件26安装在X轴第一滑板24上,第一驱动件26的输出端连接有第一齿轮263,第一齿轮263与第一齿条212啮合连接从而驱动X轴第一滑板24在第一直线导轨28上沿X轴方向移动,X轴第二横梁主体22上安装有第二直线导轨29和第二齿条213,第二滑块211能滑动地安装于第二直线导轨29上,X轴第二滑板25安装在第二滑块211上,第二驱动件27安装在X轴第二滑板25上,第二驱动件27的输出端连接有第二齿轮273,第二齿轮273与第二齿条213啮合从而驱动X轴第二滑板25在第二直线导轨29上沿X轴方向移动,Y轴组件3的两端分别安装于X轴第一滑板24和X轴第二滑板25上;Y轴组件3包括Y轴横梁主体31、第三直线导轨32、第三滑块33、第三齿条34、Y轴滑座35、第三驱动件36以及第四驱动件37,Y轴横梁主体31的两端分别安装于X轴第一滑板24和X轴第二滑板25上,第三滑块33能滑动地安装于第三直线导轨32上,第三直线导轨32和第三齿条34均安装在Y轴横梁主体31上,Y轴滑座35安装在第三滑块33上,第三驱动件36和第四驱动件37安装于Y轴滑座35上,第三驱动件36的输出端连接有第三齿轮363,第三齿轮363与第三齿条34啮合连接从而驱动Y轴滑座35沿Y轴方向移动,Z轴组件4沿Z轴方向可滑动地安装于Y轴滑座35上,第四驱动件37驱动Z轴组件4沿Z轴方向移动;Z轴组件4包括Z轴滑枕41、连接板42、连接座43、第四直线导轨44、第四滑块45以及第四齿条46,第四滑块45安装于Y轴滑座35上,第四直线导轨44、第四齿条46以及连接板42均安装在Z轴滑枕41上,第四直线导轨44能滑动地安装于第四滑块45上,第四驱动件37的输出端连接有第四齿轮373,第四齿轮373与第四齿条46啮合连接,连接座43安装在连接板42上,机械臂5包括旋转气缸51和用于夹持激光发生器的夹持部52,旋转气缸51安装于连接座43上,旋转气缸51的输出端连接夹持部52,机械臂5能在连接座43上自由转动,第四驱动件37的输出端连接有第四齿轮373,第四齿轮373与第四齿条46啮合从而驱动Z轴组件4带动机械臂5沿Z轴方向移动,从而可以高效的完成对不同形状、尺寸规格模具的淬火加工,加工过程中不需要二次装夹且相比于其他的传统设备淬火深度更加均匀,淬火精度更高。As shown in Figures 1 to 6, it is a machine tool for laser quenching of molds provided by the present invention. The machine tool includes a
在上述实施例中,X轴组件2还包括第一调整板214和第二调整板215,第一驱动件26安装在第一调整板214上,第一调整板214安装在X轴第一滑板24上,第二驱动件27安装在第二调整板215上,第二调整板215安装在X轴第二滑板25上,第一调整板214与第二调整板215上均开设有腰形孔216,X轴第一滑板24与X轴第二滑板25上均开设有连接孔,第一调整板214与X轴第一滑板24之间及第二调整板215与X轴第二滑板25之间均通过连接件穿过腰形孔216与连接孔固定连接,连接件在腰形孔216中可进行横向移动调节,使第一调整板214在X轴第一滑板24上的安装位置可调节,第二调整板215在X轴第二滑板25上的安装位置可调节,有利于调节第一驱动件26上的第一齿轮263与第一齿条212之间的间隙及第二驱动件27上的第二齿轮273与第二齿条213之间的间隙,以保证啮合连接精度,保证运动稳定性。In the above-mentioned embodiment, the
在上述实施例中,第一驱动件26包括第一伺服电机261和第一减速机262,第一伺服电机261和第一减速机262传动连接,第一减速机262与第一齿轮263传动连接,第一减速机262安装在第一调整板214上,第二驱动件27包括第二伺服电机271和第二减速机272,第二伺服电机271与第二减速机272传动连接,第二减速机272与第二齿轮273传动连接,第二减速机272安装在第二调整板215上,有利于提高输出扭矩,保证运动的稳定性。In the above embodiment, the first driving
在上述实施例中,Y轴组件3还包括第三调整板38和第四调整板39,第三驱动件36安装在第三调整板38上,第三调整板38安装在Y轴滑座35上,第四驱动件37安装在第四调整板39上,第四调整板39安装在Y轴滑座35上,第三调整板38与第四调整板39上均开设有腰形孔(图中未示出),Y轴滑座35上开设有连接孔,第三驱动件36和第四驱动件37均通过连接件穿过腰形孔与连接孔固定连接,连接件在腰形孔中可进行移动调节,使第三调整板38和第四调整板39安装在Y轴滑座35上的安装位置可调节,有利于调节第三驱动件36上的传动齿轮与第三齿条34之间的间隙及第四驱动件37上的传动齿轮与第四齿条46之间的间隙,以保证啮合连接精度,保证运动稳定性。In the above embodiment, the Y-axis assembly 3 further includes a
在上述实施例中,第三驱动件36包括第三伺服电机361和第三减速机362,第三伺服电机361和第三减速机362传动连接,第三减速机362与第三齿轮363传动连接,第三减速机362安装在第三调整板38上,第四驱动件37包括第四伺服电机371和第四减速机372,第三伺服电机361与第三减速机362传动连接,第三减速机362与第三齿轮363传动连接,第四伺服电机371安装在第四减速机372上,第四减速机372安装在第四调整板39上,有利于提高输出扭矩,保证运动的稳定性。In the above embodiment, the third driving
以上所述仅为本实用新型的较佳实施例而已,并不用以限制本实用新型,凡在本实用新型的精神和原则之内所作的任何修改、等同替换和改进等,均应包含在本实用新型的保护范围之内。The above are only preferred embodiments of the present invention, and are not intended to limit the present invention. Any modifications, equivalent replacements and improvements made within the spirit and principles of the present invention shall be included in the present invention. within the scope of protection of the utility model.
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201920209485.3U CN209957836U (en) | 2019-02-18 | 2019-02-18 | Machine tool for laser quenching of die |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201920209485.3U CN209957836U (en) | 2019-02-18 | 2019-02-18 | Machine tool for laser quenching of die |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN209957836U true CN209957836U (en) | 2020-01-17 |
Family
ID=69238515
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN201920209485.3U Active CN209957836U (en) | 2019-02-18 | 2019-02-18 | Machine tool for laser quenching of die |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN209957836U (en) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111230695A (en) * | 2020-03-26 | 2020-06-05 | 东莞台一盈拓科技股份有限公司 | Polishing machine |
| CN115094213A (en) * | 2022-07-21 | 2022-09-23 | 云南太标数控机床有限公司 | Numerical control quenching machine tool and quenching process for large-sized workpiece |
-
2019
- 2019-02-18 CN CN201920209485.3U patent/CN209957836U/en active Active
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111230695A (en) * | 2020-03-26 | 2020-06-05 | 东莞台一盈拓科技股份有限公司 | Polishing machine |
| CN115094213A (en) * | 2022-07-21 | 2022-09-23 | 云南太标数控机床有限公司 | Numerical control quenching machine tool and quenching process for large-sized workpiece |
| CN115094213B (en) * | 2022-07-21 | 2024-06-04 | 云南太标数控机床有限公司 | Numerical control quenching machine tool and quenching process for large-sized workpiece |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102126134B (en) | Five-axis five-linkage inverted turning-milling compound processing device | |
| CN103978393B (en) | A kind of parallel machine that can realize five-axis robot | |
| CN207997068U (en) | A kind of industrial robot for dimension laser cutting | |
| CN104972455A (en) | Mixed-connected robot with redundant drive based on plane parallel mechanism | |
| CN113042996A (en) | Assembling tool and assembling process for intelligent assembling and tightening workstation | |
| CN113333926A (en) | A intelligent welding machine for LNG boats and ships bunker inner wall | |
| CN220825625U (en) | Welding duplex position machine that shifts with position adjustment function | |
| CN113021003A (en) | Automatic cutting, welding and moving workstation for fire fighting pipeline | |
| CN212217764U (en) | Numerical control movable beam type five-axis gantry machining center machine tool | |
| CN221891436U (en) | A positioning and clamping structure for a gantry machining center | |
| CN217776084U (en) | Two-axis linkage robot positioner | |
| CN208083860U (en) | Teaching type five-axle number control machine tool | |
| CN215789822U (en) | Continuous positioning-free intelligent welding robot | |
| CN203900978U (en) | Parallel machine tool capable of realizing five-axis machining | |
| CN109227318A (en) | Double-station numerical control lathe | |
| CN206732565U (en) | A kind of horizontal mechanical processing work platform | |
| CN210476069U (en) | Pneumatic shaping device | |
| CN203599742U (en) | Four-axis double-station spot welding robot | |
| CN210848969U (en) | Welding tool for large and medium-sized boxes | |
| CN223917051U (en) | A welding device for parts processing | |
| CN221791428U (en) | Medical supplies welding jig and laser welding machine thereof | |
| CN209550766U (en) | Numerical control sawing machine | |
| CN222243151U (en) | A servo laser engraving fixture | |
| CN111922738A (en) | Five-axis linkage aluminum profile machining device | |
| CN221435617U (en) | Integrated processing equipment |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant | ||
| TR01 | Transfer of patent right | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20230526 Address after: 518000 No. 9988 Shennan Road, Nanshan District, Shenzhen, Guangdong Patentee after: HAN'S LASER TECHNOLOGY INDUSTRY GROUP Co.,Ltd. Patentee after: Shenzhen Han's Heguang Technology Co.,Ltd. Address before: 518000 No. 9988 Shennan Road, Nanshan District, Shenzhen, Guangdong Patentee before: HAN'S LASER TECHNOLOGY INDUSTRY GROUP Co.,Ltd. Patentee before: HAN'S LASER SMART EQUIPMENT GROUP Co.,Ltd. |
|
| TR01 | Transfer of patent right | ||
| TR01 | Transfer of patent right |
Effective date of registration: 20240228 Address after: 518000 No. 9988 Shennan Road, Nanshan District, Shenzhen, Guangdong Patentee after: HAN'S LASER TECHNOLOGY INDUSTRY GROUP Co.,Ltd. Country or region after: China Address before: 518000 No. 9988 Shennan Road, Nanshan District, Shenzhen, Guangdong Patentee before: HAN'S LASER TECHNOLOGY INDUSTRY GROUP Co.,Ltd. Country or region before: China Patentee before: Shenzhen Han's Heguang Technology Co.,Ltd. |