Disclosure of Invention
The invention mainly aims to provide a rim driving propeller of a magnetic suspension permanent magnet motor, which has the advantages of simple and compact structure, high propelling efficiency and small noise vibration.
In order to achieve the above object, the present invention provides a rim-driven propeller of a magnetically levitated permanent magnet motor, comprising a housing, a stator assembly and a rotor assembly, wherein,
the stator assembly comprises a stator yoke which is hermetically arranged in the inner cavity of the shell, and a suspension force stator winding and a torque stator winding which are arranged on the stator yoke;
the rotor assembly comprises a rotor ring, permanent magnets fixed on the outer side wall of the rotor ring and blades arranged on the inner ring side of the rotor ring, the stator assembly is located outside the rotor assembly, a gap is formed between the rotor assembly and the rotor ring, an auxiliary mechanical bearing and an axial magnetic suspension bearing are further installed between the rotor assembly and the shell, the number of pole pairs of a suspension force stator winding and a torque stator winding is unequal to form magnetic fields with the permanent magnets on the rotor ring respectively, the air gap magnetic fields of the suspension force stator winding and the permanent magnets are excited to generate suspension force to support the rotor to suspend, and the air gap magnetic fields of the torque stator winding and the permanent magnets are excited to generate electromagnetic torque to drive the motor to rotate.
Preferably, a rotating member is fixed on the outer side wall of the shell, and the end cables of the suspension force stator winding and the torque stator winding are positioned in an inner cavity of the rotating member so as to be connected with the ship body.
Preferably, the front side and the rear side of the shell are respectively connected with a front cover plate and a rear cover plate in a sealing manner, and a stator protective layer sealing ring for isolating seawater in the gap is arranged at the joint of the stator yoke and the front cover plate and the rear cover plate.
Preferably, a front guide cover and a rear guide cover are respectively and hermetically mounted on the sides of the front cover plate and the rear cover plate, which face away from each other, and guide the water flow entering the interior of the rotor ring.
Preferably, the mutually opposite sides of the front cover plate and the rear cover plate are respectively provided with an outward extending shaft in a protruding mode, an axial auxiliary mechanical bearing is installed between the front end face of the outward extending shaft and the rotor ring, and a radial auxiliary mechanical bearing is installed between the side face of the outward extending shaft and the rotor ring.
Preferably, a gap between the housing interior chamber and the stator yoke is filled with a curable material for sealing.
Preferably, the permanent magnet is coated with a permanent magnet protective layer for isolating seawater from eroding the permanent magnet on the side surface of the permanent magnet opposite to the stator assembly.
Preferably, the opposite sides of the suspension force stator winding and the torque stator winding facing the rotor ring are coated with stator protective layers for isolating corrosion of seawater to the stator, and a gap is formed between the stator protective layers and the permanent magnet protective layers.
Preferably, the outer surface of the stator shield is provided with corrugations or microgrooves.
Preferably, a plurality of blades are uniformly distributed on the inner ring side of the rotor ring, and each blade is fixedly connected with the rotor ring through a blade plate.
The magnetic suspension permanent magnet motor rim driving propeller provided by the invention has the following beneficial effects:
1. the traditional mechanical shafting propelling device is provided with intermediate links such as a gear box, a transmission shafting, sealing and the like, and the motor, the propeller, the guide pipe and the bearing are highly integrated together, so that the mechanical shafting propelling device is simpler and more compact in structure, higher in power density and high in propelling efficiency, and is suitable for being applied to a subminiature propelling system of a ship;
2. the thrust generated by the blades of the traditional rim-driven propeller is generally born by water-lubricated dynamic pressure bearings at two ends of a rotor, and for a subminiature propulsion system, the thrust is limited by a gap space between a stator and a rotor, seawater is difficult to enter or flow after entering, the water-lubricated dynamic pressure bearings are complex in structure, more in parts, difficult to install and limited in bearing capacity, but a bearingless permanent magnet synchronous motor is adopted as a driving motor, a suspension force is generated by mutual excitation of a suspension force stator winding and a permanent magnet air gap magnetic field, the effect of supporting the rotor to suspend is achieved, the noise vibration is small, the water-lubricated dynamic pressure bearings in the traditional shaftless rim-driven propeller can be replaced, and the problems are avoided;
3. the rim-driven propeller of the magnetic suspension permanent magnet motor can dynamically adjust electromagnetic suspension to realize load change through torque control and suspension force control so as to adapt to different working conditions.
Detailed Description
It should be understood that the specific embodiments described herein are merely illustrative of the invention and are not intended to limit the invention.
It should be noted that in the description of the present invention, the terms "lateral", "longitudinal", "upper", "lower", "front", "rear", "left", "right", "vertical", "horizontal", "top", "bottom", "inner", "outer", etc. indicate orientations or positional relationships based on those shown in the drawings, and are only for convenience of description and simplicity of description, and do not indicate or imply that the referred device or element must have a specific orientation, be constructed and operated in a specific orientation, and thus, should not be construed as limiting the present invention. Furthermore, the terms "first," "second," and the like are used for descriptive purposes only and are not to be construed as indicating or implying relative importance.
The invention provides a rim driving propeller of a magnetic suspension permanent magnet motor.
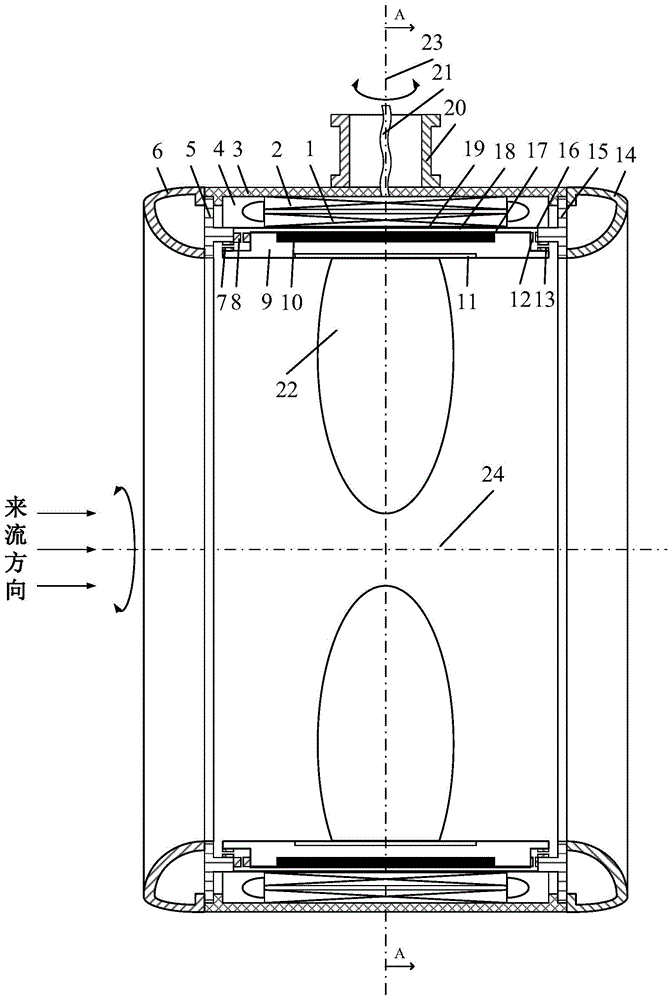
Referring to fig. 1 and 2, in the preferred embodiment, a rim-driven propeller of a magnetically levitated permanent magnet motor includes a housing 3 (the housing 3 is located at an outer ring side of a rotor assembly and has a cavity therein for mounting the stator assembly), the stator assembly and the rotor assembly, wherein,
the stator assembly comprises a stator yoke 4 which is hermetically arranged in the inner cavity of the shell 3, and a suspension force stator winding 1 and a torque stator winding 2 which are arranged on the stator yoke 4;
the rotor assembly comprises a rotor ring 9, permanent magnets 10 fixed on the outer side wall of the rotor ring 9, blades 22 installed on the inner ring side of the rotor ring 9, the stator assembly is located outside the rotor assembly, a gap is formed between the stator assembly and the rotor assembly, an auxiliary mechanical bearing (comprising a radial auxiliary mechanical bearing and an axial auxiliary mechanical bearing) and an axial magnetic suspension bearing are further installed between the rotor assembly and the shell 3, the pole pair numbers of the suspension force stator winding 1 and the torque stator winding 2 are unequal to form magnetic fields with the permanent magnets 10 on the rotor ring 9 respectively, the air gap magnetic fields of the suspension force stator winding 1 and the permanent magnets 10 are excited mutually to generate suspension force to support rotor suspension, and the air gap magnetic fields of the torque stator winding 2 and the permanent magnets 10 are excited mutually to generate electromagnetic torque to drive the motor to rotate. The gap between the stator yoke 4 and the permanent magnets 10 on the rotor ring 9 is the air gap 18.
Specifically, a rotating member 20 is fixed on the outer side wall of the housing 3, and the end cables 21 of the levitation force stator winding 1 and the torque stator winding 2 are each located in an inner chamber received in the rotating member 20 to be connected to the hull.
Referring to fig. 2, square grooves (4 square grooves are illustrated in fig. 2) are formed in the outer wall of the rotor ring 9 at equal intervals, and the permanent magnets 10 are embedded in the square grooves.
When the suspension force stator winding 1 is electrified, the suspension force stator winding 1 and the permanent magnet 10 are excited by the air gap magnetic field to generate suspension force, and the effect of supporting the rotor to suspend is achieved. After the torque stator winding 2 is electrified, the torque stator winding 2 and the air gap magnetic field of the permanent magnet 10 are mutually excited to generate electromagnetic torque, so that the motor is driven to rotate, and the paddle 22 is driven to generate thrust. The axial suspension force and the blade 22 thrust force jointly act on the rotor ring 9 and finally act on the ship body through the rotating member 20 connected with the shell 3, and further the ship is propelled to advance. The upper end of the rotating part 20 is provided with a swing mechanism, so that the propeller can rotate 360 degrees around the vertical axis in all directions.
Further, referring to fig. 1, a front cover plate 5 and a rear cover plate 15 are respectively connected to the front and rear sides of the housing 3 in a sealing manner, and a stator protective layer 19 sealing ring 16 for isolating seawater in the gap is installed at the joint of the stator yoke 4 and the front cover plate 5 and the rear cover plate 15.
Further, referring to fig. 1, a front cowl 6 and a rear cowl 14 are hermetically connected to sides of the front cowl 5 and the rear cowl 15 facing away from each other, respectively, and the front cowl 6 and the rear cowl 14 guide a flow of water entering the inside of the rotor ring 9. The inner ring sides of the front guide hood 6 and the rear guide hood 14 are arc-shaped plates to guide the water flow.
In this embodiment, referring to fig. 1, the mutually opposite sides of the front cover plate 5 and the rear cover plate 15 are both provided with protruding shafts, axial auxiliary mechanical bearings (rear axial auxiliary mechanical bearings 12) are installed between the front end surfaces of the protruding shafts and the rotor ring 9, and radial auxiliary mechanical bearings (including the front radial auxiliary mechanical bearings 7 and the rear radial auxiliary mechanical bearings 13) are installed between the side surfaces of the protruding shafts and the rotor ring 9.
Specifically, a front radial auxiliary mechanical bearing 7 and a front axial magnetic suspension bearing 8 are arranged on the outer extending shaft of the front cover plate 5, and a rear axial auxiliary mechanical bearing 12 and a rear radial auxiliary mechanical bearing 13 are arranged on the outer extending shaft of the rear cover plate 15.
The front cover plate 5 and the rear cover plate 15 are both in annular plate-shaped structures, and an outward extending shaft is fixed on the end face of each annular plate. The middle of the annular structure of the front cover plate 5 and the rear cover plate 15 is used for water flow.
When the motor windings are not energized, the auxiliary mechanical bearings act to support the rotor assembly, providing radial and axial protection against damage to the rotor assembly. When the suspension force stator winding 1 is electrified, the suspension force stator winding 1 generates corresponding radial suspension force to support the rotor assembly, at the moment, the auxiliary mechanical bearing does not work, the motor rotor can run at high speed, and mechanical friction and abrasion are avoided, so that noise vibration is greatly reduced.
The bearing bushes of the radial auxiliary mechanical bearing and the axial auxiliary mechanical bearing comprise a radial bush and a thrust bush, the bearing bush substrates are made of stainless steel, and the surfaces of the bearing bushes are made of rubber or high polymer materials. The rotor carrier (i.e. the part of the bearing connected to the rotor, i.e. the bearing bush opposite to the rotor carrier, which together form a bearing) is made of bronze or a metal alloy, and the front axial magnetic levitation bearing 8 is used for transmitting the thrust of the blade 22 when the motor is in operation.
Further, the gap between the stator yoke 4 and the inner cavity of the housing 3 is filled with a curable material (the curable material may be an epoxy resin or a sealant) for sealing, so that the sealing performance of the housing 3 and the stator yoke 4 is further improved.
Further, the permanent magnet 10 is coated with a permanent magnet protective layer 17 for isolating seawater from eroding the permanent magnet 10 on the side opposite to the stator assembly; the opposite side surfaces of the suspension force stator winding 1 and the torque stator winding 2 facing the rotor ring 9 are coated with a stator protective layer 19 for isolating corrosion of seawater to the stator, a gap is arranged between the stator protective layer 19 and the permanent magnet protective layer 17, and during work, the seawater cools the bearingless permanent magnet synchronous motor through the gap.
The outer surface of the stator shield 19 is provided with corrugations or microgrooves. The stator shield 19 does not have a negative effect on the magnetic field, while the thickness cannot be too large and heat dissipation is easy.
Specifically, referring to fig. 2, a plurality of blades 22 are uniformly distributed on the inner ring side of the rotor ring 9, and each blade 22 is fixedly connected with the inner side wall of the rotor ring 9 through a blade plate 11. The figure is illustrated in detail by way of example in which the rotor ring 9 is provided with 4 blades 22.
The torque control subsystem controls electromagnetic torque by adjusting the current of the stator winding, and the suspension force control subsystem dynamically adjusts electromagnetic suspension to realize load change by adopting double closed-loop control so as to dynamically adapt to different working conditions.
The magnetic suspension permanent magnet motor rim-driven propeller has the following working principle: after the stator winding is electrified, the suspension force stator winding 1, the torque stator winding 2 and the permanent magnet 10 form a bearingless permanent magnet synchronous motor. After the suspension force stator winding 1 is electrified, the suspension force stator winding 1 and the permanent magnet 10 air gap magnetic field are mutually excited to generate suspension force, the effect of supporting the rotor to suspend is achieved, meanwhile, after the torque stator winding 2 is electrified, the torque stator winding 2 and the permanent magnet 10 air gap magnetic field are mutually excited to generate electromagnetic torque, and therefore the driving motor rotates to drive the blades 22 to generate thrust, and the ship body is driven to sail.
The magnetic suspension permanent magnet motor rim driving propeller provided by the invention has the following beneficial effects:
1. the traditional mechanical shafting propelling device is provided with intermediate links such as a gear box, a transmission shafting, sealing and the like, and the motor, the propeller, the guide pipe and the bearing are highly integrated together, so that the mechanical shafting propelling device is simpler and more compact in structure, higher in power density and high in propelling efficiency, and is suitable for being applied to a subminiature propelling system of a ship;
2. the thrust generated by the blades 22 of the traditional rim-driven propulsion device is generally born by water-lubricated dynamic pressure bearings at two ends of a rotor, and for a subminiature propulsion system, the thrust is limited by a gap space between a stator and a rotor, seawater is difficult to enter or flow after entering, the water-lubricated dynamic pressure bearings are complex in structure, more in parts, difficult to install and limited in bearing capacity, but a bearingless permanent magnet synchronous motor is adopted as a driving motor, and a suspension force is generated by mutual excitation of air gap magnetic fields of a suspension force stator winding 1 and a permanent magnet 10, so that the effect of supporting the rotor to suspend is achieved, the noise vibration is small, the water-lubricated dynamic pressure bearings in the traditional shaftless rim-driven propeller can be replaced, and the problems are avoided;
3. the rim-driven propeller of the magnetic suspension permanent magnet motor can dynamically adjust electromagnetic suspension to realize load change through torque control and suspension force control so as to adapt to different working conditions.
The above description is only for the preferred embodiment of the present invention and is not intended to limit the scope of the present invention, and all equivalent structural changes made by using the contents of the present specification and the drawings, or any other related technical fields, are intended to be covered by the scope of the present invention.