Disclosure of Invention
The invention overcomes one of the defects of the prior art, and provides a tensioning integral frame and an impact-resistant unmanned aerial vehicle, wherein the frame is light and can provide high-strength impact resistance, the influence on the endurance of the unmanned aerial vehicle is reduced while the mechanical structure of the unmanned aerial vehicle is protected, and flight control can generate a corresponding driving strategy according to the current posture to drive a propeller of the unmanned aerial vehicle to generate thrust, so that the unmanned aerial vehicle can orderly and controllably roll on the ground and realize take-off again after falling.
According to one aspect of the disclosure, the invention provides a six-rod tensioning integral frame, which comprises six rigid compression rods and twenty-four elastic cables, wherein four elastic cables are led out from two end points of each rigid compression rod respectively, and the four elastic cables at each end point are connected with four end points nearest to the end point respectively; the six rigid compression bars are divided into three groups on average, any two groups of rigid compression bars in the three groups of rigid compression bars are perpendicular to each other in spatial position, and the two rigid compression bars in each group are parallel to each other.
In a possible implementation manner, the rigid compression bar includes a hollow carbon tube and a bar cable connector, the bar cable connector is respectively disposed at two ends of the hollow carbon tube, and the bar cable connector and the hollow carbon tube are fixedly connected through interference fit.
In one possible implementation, the rod and cable connector comprises a 3D print, a bearing, a rubber ring, a snap spring groove; the 3D prints the piece and is provided with protruding post, be carved with the jump ring groove on the protruding post, the jump ring is laid in the jump ring groove for it is fixed the bearing, the outside of bearing is provided with the rubber circle.
In a possible implementation manner, the upper part of the rod and cable connecting piece is arc-shaped, and six through holes are formed in the rod and cable connecting piece.
In one possible implementation, the elastic cord comprises a spring, a nylon cord, and a cord locker; the hooks at the two ends of the spring are respectively connected with two sections of nylon ropes with the same length, and the nylon ropes are fixedly connected with the spring hooks through the thread locking device.
In a possible implementation manner, the thread locking device is further used for fixedly connecting the nylon rope with the through hole in the rod rope connecting piece.
According to another aspect of the present disclosure, the present disclosure proposes an impact resistant unmanned aerial vehicle comprising an unmanned aerial vehicle and the six-bar tensioned monolithic frame of any one of claims 1 to 6, wherein the unmanned aerial vehicle is located inside the six-bar tensioned monolithic frame, the unmanned aerial vehicle comprising a horn, a propeller, a battery, a flying tower; the tail end of an arm of the unmanned aerial vehicle is provided with a through hole, the battery is arranged below the plane where the propeller is located, and the flying tower is arranged above the plane where the propeller is located; a silica gel column is arranged between the unmanned aerial vehicle and the hollow carbon tube, and a through hole is formed in the middle of the silica gel column; and the nylon rope is utilized to be connected and fixed with the unmanned aerial vehicle and the six-rod tensioning integral frame through the through hole at the tail end of the machine arm, the silica gel column through hole and the hollow carbon tube.
The six-rod tensioning integral frame comprises six rigid compression rods and twenty-four elastic cables, wherein the four elastic cables are led out from two end points of each rigid compression rod respectively, the four elastic cables at each end point are connected with four end points nearest to the end points respectively, the six rigid compression rods are divided into three groups on average, any two groups of rigid compression rods in the three groups of rigid compression rods are perpendicular to each other in spatial position, and the two rigid compression rods in each group are parallel to each other. Can provide the shock resistance of high strength, reduce the influence to unmanned aerial vehicle duration when protecting unmanned aerial vehicle mechanical structure, make this unmanned aerial vehicle can fly in the air, carry out orderly controllable roll and take off once more after dropping on ground.
Detailed Description
The following detailed description of the embodiments of the present invention will be provided with reference to the accompanying drawings and examples, so that how to apply the technical means to solve the technical problems and achieve the corresponding technical effects can be fully understood and implemented. The embodiments and the features of the embodiments can be combined without conflict, and the technical solutions formed are all within the scope of the present invention.
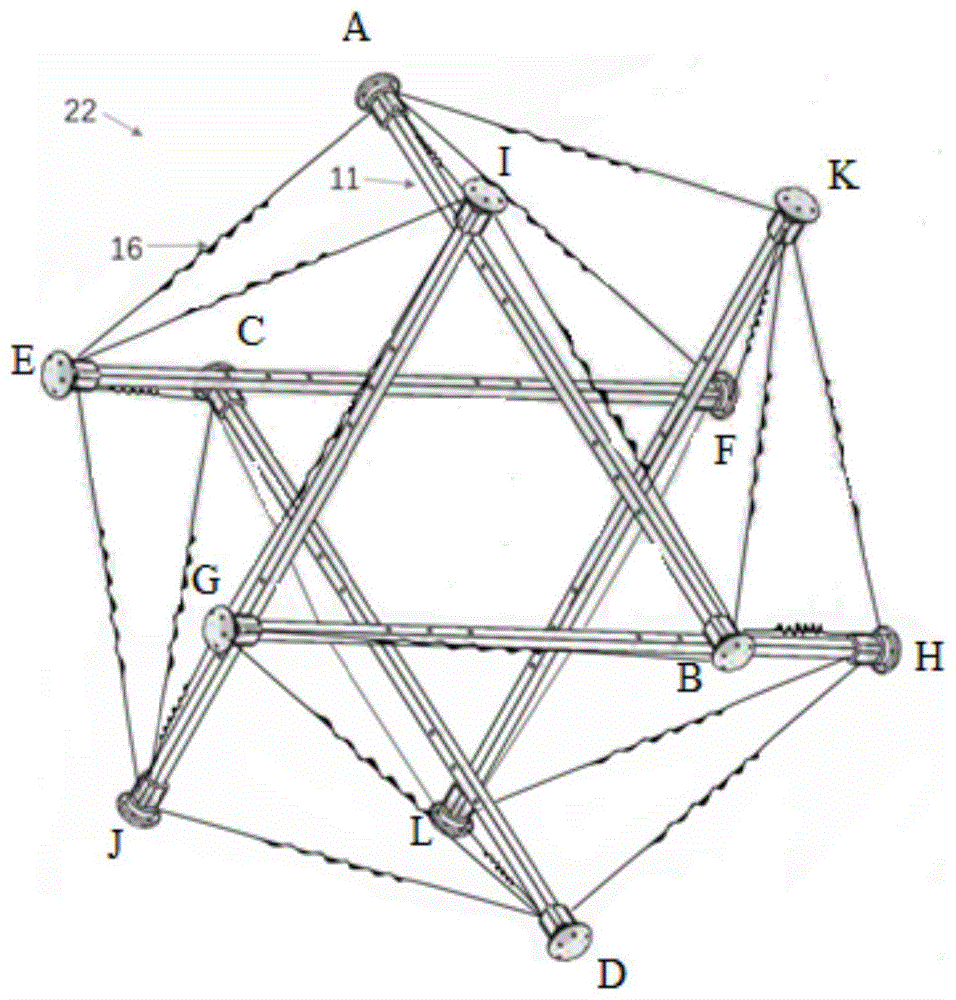
FIG. 1 shows a schematic structural view of a six bar tensioned monolithic frame according to an embodiment of the present disclosure. As shown in fig. 1, the six-bar tensioned monolithic frame may include: the device comprises six rigid pressure rods and twenty-four elastic cables, wherein the four elastic cables are led out from two end points of each rigid pressure rod respectively, and the four elastic cables at each end point are connected with the four end points closest to the end point respectively. The rigidity depression bar bears the pressure along the rigidity depression bar direction, and the elastic cord bears the pulling force, and whole structure can not produce the moment of torsion in inside because of the effect of external force, can absorb external impact force through self deformation when receiving external impact, has extremely strong shock resistance. The six rigid compression bars are divided into three groups on average, any two groups of the three groups of rigid compression bars are perpendicular to each other in spatial position, and the two rigid compression bars in each group are parallel to each other. The six-rod tensioning integral frame is highly symmetrical in space, and is a regular icosahedron in appearance, and comprises twenty triangles including eight equilateral triangles and twelve isosceles triangles.
For example, as shown in fig. 1, four elastic cables are led out from the end of each rigid compression rod, and are respectively connected with the four ends of the rigid compression rod which are closest to the end of the rigid compression rod in spatial position, so as to form a highly symmetrical regular icosahedron structure. The end point A of the rigid pressure rod is connected with the end point E, F, I, K of the nearest four rigid pressure rods, the end point B of the rigid pressure rod is connected with the end point G, H, I, K, the end point C of the rigid pressure rod is connected with the end point E, F, J, L of the nearest four rigid pressure rods, the end point D of the rigid pressure rod is connected with the end point G, H, J, L of the nearest four rigid pressure rods, the end point E of the rigid pressure rod is connected with the end point A, C, I, J of the nearest four rigid pressure rods, the end point F of the rigid pressure rod is connected with the end point A, C, K, L of the nearest four rigid pressure rods, the end point G of the rigid pressure rod is connected with the end point J, I, B, D of the nearest four rigid pressure rods, the end point H of the rigid pressure rod is connected with the end point B, D, K, L of the nearest four rigid pressure rods, the end point I of the end point A of the nearest four rigid pressure rods, the end point B of the rigid pressure rods is connected with the end point B, D, K, L of the rigid pressure rods, and the end point I of the rigid pressure rods, B. E, G, the end point J of the rigid compression rod is connected with the end point C, D, E, G of the nearest four rigid compression rods, the end point K of the rigid compression rod is connected with the end point A, B, F, H of the nearest four rigid compression rods, and the end point L of the rigid compression rod is connected with the end point C, D, F, H of the nearest four rigid compression rods.
FIG. 2 illustrates a schematic structural view of a rigid compression bar of a six bar tensioned unibody frame according to an embodiment of the present disclosure. Fig. 3, 4, 5 show a side view, a cross-sectional view, and an assembled structural cross-sectional view, respectively, of a rod and cable connection of a six-rod tensioned monolithic frame according to an embodiment of the present disclosure.
As shown in fig. 2, the rigid compression bar comprises a hollow carbon tube 11 and a bar cable connector 9, the bar cable connector 9 is respectively disposed at two ends of the hollow carbon tube 11, and the bar cable connector 9 and the hollow carbon tube 11 are fixedly connected by interference fit.
As shown in fig. 3, 4 and 5, the rod and cable connector 9 can be composed of a 3D printing piece, a bearing 15, a rubber ring 13 and a clamp spring groove 14. The 3D prints the resin joint that the piece can print out for utilizing 3D, installs the both ends of rigidity depression bar, and 3D prints built-in bearing 15 of piece and rubber circle 13, can avoid the production of moment of torsion on the rigidity depression bar, improves the shock resistance of rigidity depression bar end and to the buffer capacity of external force.
The 3D prints the piece and can be used for fixed hollow carbon pipe 11, and the 3D prints the piece and is provided with protruding post, is carved with jump ring groove 14 on the protruding post, and jump ring is laid in jump ring groove 14 for fixing bearing 15, bearing 15 can rotate around the fixed axle, are used for balancing the moment of torsion between the four elastic cables that every rigid compression bar both ends are connected, produce extra moment of torsion in hollow carbon pipe 11 inside when preventing to assemble overall structure. The rubber ring 13 is arranged on the outer side of the bearing 15, and the rubber ring 13 can buffer impact force on two end points of the rigid pressure rod, so that the impact bearing capacity of the rod end of the rigid pressure rod is improved. Wherein, the upper part of the rod and cable connecting piece is arc-shaped, and six through holes 12 are arranged on the rod and cable connecting piece and are used for connecting the nylon rope.
FIG. 6 illustrates a schematic structural view of a spring cable of a six bar tensioned unibody frame according to an embodiment of the present disclosure; fig. 7 illustrates a schematic structural view of a spring line of a six-bar tensioned monolithic frame according to another embodiment of the present disclosure.
As shown in fig. 6 and 7, the elastic cord includes a spring 16, a nylon cord 17, and a cord locker 18. The spring 16 generates tension, and the nylon rope 16 is installed by the thread locking device 18. The hooks at the two ends of the spring 16 are respectively connected with two nylon ropes 17 with the same length, and the nylon ropes 17 are fixedly connected with the spring hooks through the thread locking device 18. The thread locking device 18 is also used for fixedly connecting the nylon rope 17 with the through hole 12 on the rod rope connecting piece, so that the elastic rope is connected with the rigid pressure rod.
The tensioning integral frame comprises six rigid compression bars and twenty-four elastic ropes, wherein the four elastic ropes are led out from two end points of the rigid compression bars respectively, the four elastic ropes led out from each end point are connected with four end points nearest to the end points respectively, the six rigid compression bars are divided into three groups on average, any two groups of rigid compression bars in the three groups of rigid compression bars are perpendicular to each other in spatial position, and the two rigid compression bars in each group are parallel to each other. The high-strength impact resistance can be provided, and the influence on the cruising ability of the unmanned aerial vehicle is reduced while the mechanical structure of the unmanned aerial vehicle is protected; six pole stretch-draw whole frame high symmetry, the frame is stable can drive unmanned aerial vehicle's screw and produce thrust, makes this unmanned aerial vehicle can carry out orderly controllable roll and take off once more on ground.
In the space, the inside great load space that has of six pole stretch-draw whole frame can carry on power device and load, for example can carry on unmanned aerial vehicle etc. and the unmanned aerial vehicle that six pole stretch-draw whole frame combinations carried can be said to possess the novel unmanned aerial vehicle that shocks resistance of external impact.
Fig. 8, 9 show a single drone structure top and side views, respectively, according to an embodiment of the present disclosure.
As shown in fig. 8 and 9, an impact resistant drone comprises a drone and a six-bar tensioned monolithic frame as claimed in any one of claims 1 to 6. The unmanned aerial vehicle can include a horn, a propeller 1, a battery 6, a flying tower 3; the tail end of an arm of the unmanned aerial vehicle is provided with a through hole, the battery 6 is arranged below the plane where the propeller 1 is located, and the flying tower 3 is arranged above the plane where the propeller 1 is located; a silica gel column is arranged between the unmanned aerial vehicle and the hollow carbon tube 11, and a through hole is arranged in the middle of the silica gel column; the nylon rope 17 is connected and fixed with the unmanned aerial vehicle and the six-rod tensioning integral frame 22 through a machine arm tail end through hole, a silica gel column through hole and a hollow carbon tube connection 11.
Wherein, unmanned aerial vehicle fuselage structure to utilize the carbon fiber board of light, high strength to cut, reserve mounting hole 21 respectively at the end of four horn and be used for connecting fixed unmanned aerial vehicle and hollow carbon pipe 11, it is that unmanned aerial vehicle does not confine to four wing unmanned aerial vehicle to need to explain.
As shown in fig. 10, a partially hollow area is dug out below the propeller 1 of the drone to increase the total thrust generated by the propeller 1. Fly tower 3 that constitutes by electricity accent and fly accuse fixes in the fuselage top, and unmanned aerial vehicle's battery 6 is placed in the battery case, through battery fixed plate 7 and copper post 8 and bolt fastening in unmanned aerial vehicle's fuselage below for unmanned aerial vehicle's whole focus is located 1 place plane below of screw, makes unmanned aerial vehicle more stable by the control in-process. The silica gel column 19 is formed by model reverse molding, the upper part of the silica gel column 19 is contacted with the arm of the unmanned aerial vehicle, the lower part is contacted with the rigid compression bar, the middle part of the silica gel column 19 is provided with a through hole, and the nylon rope 17 passes through the through hole at the tail end of the arm, the through hole of the silica gel column and the hollow carbon tube for fixing.
Figure 10 illustrates a top view of an impact resistant drone according to an embodiment of the present disclosure; figure 11 illustrates a side view of an impact resistant drone according to an embodiment of the present disclosure; figure 12 shows a schematic overall structure of an impact resistant drone according to an embodiment of the present disclosure; fig. 13 shows a schematic connection diagram of an impact resistant drone and a rigid ram according to an embodiment of the present disclosure.
As shown in fig. 10 and 11, two parallel rigid compression bars are used as fixing seats for fixing the unmanned aerial vehicle, and the unmanned aerial vehicle is fixed inside the six-bar tensioning integral frame 22, as shown in fig. 12. Four elastic cables are led out from the rod cable connecting piece 9 at the tail end of each rigid compression rod of the unmanned aerial vehicle and are respectively connected with the four rod cable connecting pieces 9 which are closest to the tail end of the rod in spatial position, so that a highly symmetrical regular icosahedron structure is formed. As shown in fig. 13, the unmanned aerial vehicle has no direct contact with the hollow carbon tube 11 in the six-bar tension unit 22.
Fixing the unmanned aerial vehicle inside the six-rod tensioning integral frame, connecting the elastic cable with the rigid compression bar, wherein the spring 16 is in an extension state during connection, namely, the elastic cable is internally provided with a pretightening force in the assembling process, the pretightening force is used for maintaining the structural shape of the six-rod tensioning integral frame, the tension in each elastic cable is basically consistent in size, and the surface of the six-rod tensioning integral frame is in a regular icosahedron shape in space.
In an initial state before normal takeoff, any one of twenty surfaces of the six-rod tensioning integral frame 22, which is located below a plane where the propeller 1 of the unmanned aerial vehicle is located, lands, the plane where the propeller 1 of the unmanned aerial vehicle is located is inclined and has a certain included angle with the ground, when the unmanned aerial vehicle is ready to take off, the unmanned aerial vehicle enters a self-stabilizing mode, the propeller 1 rotates and generates thrust, and the plane where the propeller 1 is located is parallel to the ground, so that the unmanned aerial vehicle can take off normally; after taking off, an operator controls the remote controller to realize the control of the invention and realize the functions of detecting, transporting loads and the like.
After the unmanned aerial vehicle impacts a barrier, the shell of the six-rod tensioning whole 22 absorbs the impact force of the barrier on the unmanned aerial vehicle, and after the unmanned aerial vehicle falls to the ground, the impact force is greatly buffered by virtue of the spring 16, the rubber ring 13 and the like, so that the protection of the structures such as the propeller 1 and the horn is realized; rely on flying to control inside sensor data and realize discerning unmanned aerial vehicle self gesture, judge and land on ground and generate corresponding screw 1 drive strategy at present for novel unmanned aerial vehicle that shocks resistance based on six pole stretch-draw overall frame carries out orderly controllable roll on ground, finally overturns the gesture that is fit for taking off, realizes that unmanned aerial vehicle receives the striking to land after taking off once more.
Although the embodiments of the present invention have been described above, the above descriptions are only for the convenience of understanding the present invention, and are not intended to limit the present invention. It will be understood by those skilled in the art that various changes in form and details may be made therein without departing from the spirit and scope of the invention as defined by the appended claims.