CN102233463A - Wire winding system and wire supply method for wire cutting machine - Google Patents
Wire winding system and wire supply method for wire cutting machine Download PDFInfo
- Publication number
- CN102233463A CN102233463A CN 201010158106 CN201010158106A CN102233463A CN 102233463 A CN102233463 A CN 102233463A CN 201010158106 CN201010158106 CN 201010158106 CN 201010158106 A CN201010158106 A CN 201010158106A CN 102233463 A CN102233463 A CN 102233463A
- Authority
- CN
- China
- Prior art keywords
- wire
- winding system
- utmost point
- actuating device
- cutting machine
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images





Landscapes
- Electrical Discharge Machining, Electrochemical Machining, And Combined Machining (AREA)
Abstract
Description
技术领域 technical field
本发明涉及一种线切割加工机之绕线系统及其供线方法。 The invention relates to a wire winding system of a wire cutting machine and a wire supply method thereof. the
背景技术 Background technique
传统线切割加工机之绕线系统,皆为线极经由供线轮,依序绕过滚轮、煞车轮、滚轮、及收线轮,而此种供线方式,是为利用收线轮马达旋转,带动其他滚轮,让全段线极,呈现一高张力的状态,但此方法,只适用于粗线极的线切割加工机。 The winding system of the traditional wire cutting processing machine is that the wire passes through the wire supply wheel, and then bypasses the roller, the brake wheel, the roller, and the take-up wheel in sequence, and this kind of wire supply method is to use the take-up wheel motor to rotate , to drive other rollers, so that the entire wire pole presents a state of high tension, but this method is only suitable for wire cutting machines with thick wire poles. the
而随着产业迈向精密化,各种零件之加工质量,亦要求精细与高精度,对于线切割加工机而言,欲提升加工精度与加工精密零件,必须使用较细线径之线极加工。 As the industry moves towards precision, the processing quality of various parts also requires fineness and high precision. For wire cutting machines, in order to improve the processing accuracy and process precision parts, it is necessary to use thinner wire diameter wire processing. . the
由于细线之降伏强度(Yield Strength)较低,所能承受之线张力不高,故线张力必须控制于较低值,以避免断线状况产生,但目前现有之供线轮,皆有相当大的质量与尺寸,欲以较细的线极带动供线轮,势必产生较大的线张力扰动,及有容易断线的问题,会影响其加工质量。 Due to the low Yield Strength of the thin thread, the thread tension it can withstand is not high, so the thread tension must be controlled at a low value to avoid thread breakage. However, the existing thread supply reels currently have Considerable mass and size, if you want to use a thinner wire pole to drive the wire supply wheel, it will inevitably cause a large wire tension disturbance, and there will be problems of easy wire breakage, which will affect its processing quality. the
因此,业者开始针对以上问题,发展微线极的线切割加工机之绕线系统,以降低供线轮转动惯量,使加工机可以低张力加工,且避免其细线拉伸,产生之低频扰动的问题,不断的进行线切割加工机之绕线系统的改良,而其改进方式众多,故藉由以下的三个技术文献,来做为代表。 Therefore, the industry began to address the above problems and develop the winding system of the micro-wire wire cutting machine to reduce the moment of inertia of the wire supply wheel, so that the processing machine can process with low tension, and avoid the low-frequency disturbance caused by the thin wire stretching To solve the problem, the winding system of the wire cutting machine is continuously improved, and there are many ways to improve it, so the following three technical documents are used as representatives. the
关于此方面的第一个技术文献,可参考下列中国台湾专利公告第M357332号「线切割式放电加工机的切割线的张力控制器」、公元2009年05月21日所公告的专利文献1所示,为一种线切割式放电加工机的切割线的张力控制器,包含:一基板;一马达,装设在该基板的一侧,且该马达具一轴心,该轴心贯穿该基板向该基板的另一侧穿出;一张力轮,装设在该马达的轴心外,且该张力轮与该马达的轴心绝缘;二电刷,彼此分离且装设在该基板上,该二电刷并分别接触该张力轮,使电流能经由该二电刷传导至该张力轮;三导线轮,分别枢设在该基板的另一侧;以及一压线皮带,绕设在该三导线轮外,且该压线皮带的外侧压靠在该张力轮上,该切割线则夹在该压线皮带与该张力轮之间,以该马达的轴心连动该张力轮枢转,并带动该压线皮带与该三导线轮作动,便能连动输送该切割在线控制该切割线的张力 保持在预设的范围内;
Regarding the first technical document in this regard, you can refer to the following Taiwan Patent Announcement No. M357332 "Tension Controller of the Cutting Wire of a Wire-cut EDM",
其中,专利文献1为使用皮带输送的方式,将线极压附于滚轮上,使线极不易脱离,并减少其张力扰动。
Among them,
关于此方面的第二个技术文献,可参考下列中国台湾专利公告第I254659号「线切割放电加工机构」、公元2006年05月11日所公告的专利文献2所示,为一种线切割放电加工机构,其包括:一基板,一端装置一线轴,另一端装置一马达及与马达同轴心之线轴,基板于大平面处横向开设若干定位孔/槽;一斜角切割调整机构,系以一斜角切割定位机构将之固定于基板,并于该机构之大平面处横向开设若干定位孔/槽,斜角切割调整机构可平行于基板大平面方向调整角度,以切割不同的斜角;一倾角切割调整机构,系以一倾角切割定位机构将之固定于斜角切割调整机构上,并于该机构之大平面处纵向开设若干定位孔/槽,倾角切割调整机构可平行于基板大平面方向调整角度,以切割不同的倾角;一压条机构,系以一压条机构固定组件将之固定于基板大平面,并使压条与水平线成一小夹角,压条下方设置一可以滚动之基轮。
Regarding the second technical document in this regard, you can refer to the following Taiwan Patent Announcement No. I254659 "Wire Cutting EDM Mechanism", as shown in
其中,专利文献2为将供线轮加装一马达,使供线轮主动旋转供线,以利用收线轮及供线轮之转速差,控制其张力送线。
Among them,
关于此方面的第三个技术文献,可参考下列中国台湾专利公告第200841971号「线切割机供线控制装置/CONTROL DEVICE OF PROVIDING WIRE FOR CUTTINGMACHINE」,公元2008年11月01日所公告的专利文献3所示,为一种线切割机供线控制装置,该线切割机系令一铜线由一供线轮输出后可利用一夹线轮组将铜线导入被切割件上、下方之上、下模眼,最后使用后之铜线并一收线轮组卷收;而供线控制装置系于供线轮与夹线轮组间设有一检知单元,该检知单元具有一可依铜线张力而上、下移动之活动滑轮,且机体于对应活动滑轮可移动之下方位置处设有一检测组件,该检测组件可选择性检知活动滑轮因铜线张力变小而下降,并发出控制讯号。 Regarding the third technical document in this regard, you can refer to the following patent document published on November 01, 2008 in Taiwan Patent Announcement No. 200841971 "Wire Cutting Machine Wire Supply Control Device/CONTROL DEVICE OF PROVIDING WIRE FOR CUTTING MACHINE" As shown in 3, it is a wire supply control device for a wire cutting machine. After a copper wire is output by a wire supply wheel, a wire clamping wheel group can be used to guide the copper wire into the upper and lower parts of the cut piece. , the lower mold eye, and the copper wire after the last use is taken up by a take-up wheel set; and the wire supply control device is provided with a detection unit between the wire supply wheel and the wire clamping wheel set. The movable pulley moves up and down with the tension of the copper wire, and the body is equipped with a detection component at the lower position where the corresponding movable pulley can move. control signal. the
其中,专利文献3为位于供线轮处,加装一扭力马达,并于供线轮与煞车轮之间,装设一传感器,使供线避免松脱。
Among them,
前述专利文献1、2、3中,存在着下列问题点:
In the
专利文献1、2、3之中,所使用的供线方法与绕线系统,虽然各有各的优点,但是依旧无法直接隔绝供线轮的转动惯量,一旦供线轮的转动惯量过大,系统的自然频率(natural frequency),便会落于低频带处,当自然频率过低,系统就容易受到干扰、产生不稳定的问题。
In
有鉴于此,如何隔离供线轮的转动惯量,以解决供线轮之转动惯量过大,使系统不稳定,产生张力扰动之问题,便成为本发明欲改进的目的。 In view of this, how to isolate the moment of inertia of the wire supply wheel to solve the problem that the moment of inertia of the thread supply wheel is too large, making the system unstable and generating tension disturbances has become the object of the present invention. the
发明内容 Contents of the invention
本发明目的在于提供一种用于微线极之线切割加工机,能以低张力运作加工、且使线张力更稳定的线切割加工机之绕线系统及其供线方法。 The purpose of the present invention is to provide a wire cutting machine for micro-wire poles, which can operate and process with low tension and make the wire tension more stable. The winding system and wire supply method of the wire cutting machine. the
本发明是采用以下技术手段实现的: The present invention is realized by adopting the following technical means:
本发明技术手段,在系统方面,为一种线切割加工机之绕线系统,其特征在于包括: The technical means of the present invention, in terms of system, is a winding system of a wire cutting machine, which is characterized in that it includes:
一能与线切割加工机连接的绕线系统面板(1); A winding system panel (1) capable of being connected to the wire cutting machine;
一设于该绕线系统面板(1)一侧的致动装置(2); An actuating device (2) located on one side of the winding system panel (1);
一相对于该致动装置(2)、轴接于该绕线系统面板(1)另一侧面,并能被该致动装置(2)带动,以供输出一能让线切割加工机所使用之线极(W)的供线轮(3); One is connected to the other side of the winding system panel (1) relative to the actuating device (2), and can be driven by the actuating device (2) for output; one can be used by a wire cutting machine The wire supply wheel (3) of the wire pole (W);
一设于该绕线系统面板(1)、与供线轮(3)同侧之线极(W)输出端处,并具有一轴线与该供线轮(3)轴线平行之张力滚轮(41),能调整张力滚轮(41)松紧程度、以使后段线极(W)产生张力的线极夹持机构(4); One is located at the output end of the wire pole (W) on the same side of the winding system panel (1) as the wire supply wheel (3), and has a tension roller (41) whose axis is parallel to the axis of the wire supply wheel (3) ), which can adjust the tightness of the tension roller (41) so that the rear section of the wire (W) can generate tension for the wire pole clamping mechanism (4);
一设于致动装置(2)与线极夹持机构(4)之间,能感测线极(W)之上、下位置,并回授一讯号给致动装置(2),让致动装置(2)可以调整其转速快、慢的传感器装置(5);以及 One is located between the actuating device (2) and the wire clamping mechanism (4), which can sense the upper and lower positions of the wire (W), and feed back a signal to the actuating device (2), so that the The moving device (2) can adjust the fast and slow sensor device (5) of its rotating speed; and
至少一设于线极夹持机构(4)远离致动装置(2)侧处,能将线极夹持机构(4)所导出之线极(W)转向的惰轮(6)。 At least one idler wheel (6) is provided on the side of the wire clamping mechanism (4) away from the actuator (2), capable of turning the wire (W) led out by the wire clamping mechanism (4). the
根据上述的线切割加工机之绕线系统,所述线极夹持机构(4),更包括一设于该张力滚轮(41)接近致动装置(2)侧处,并与该张力滚轮(41)相接触,能对张力滚轮(41)加压、以调整张力滚轮(41)松紧程度的煞车块(42); According to the wire winding system of the above-mentioned wire cutting machine, the wire pole clamping mechanism (4) further includes a device located at the side of the tension roller (41) close to the actuator (2) and connected to the tension roller ( 41) are in contact with each other, and can pressurize the tension roller (41) to adjust the brake block (42) of the tension roller (41) degree of tightness;
一设于该煞车块(42)不与张力滚轮(41)相接触之端处,能带动煞车块(42)移动位移、以对张力滚轮(41)加压的滑动支架(43);及 One is located at the end of the brake block (42) not in contact with the tension roller (41), which can drive the brake block (42) to move and displace, so as to pressurize the tension roller (41) sliding bracket (43); and
一与该滑动支架(43)连接,能带动滑动支架(43)移动位移的致动器(44); One is connected with this sliding support (43), can drive the actuator (44) of sliding support (43) mobile displacement;
而所述绕线系统面板(1)相对于该滑动支架(43)处,更设有一能供滑动支架(43)定位与滑移的第一开槽(11)。 The winding system panel (1) is further provided with a first slot (11) for positioning and sliding of the sliding bracket (43) relative to the sliding bracket (43). the
根据上述的线切割加工机之绕线系统,所述线极夹持机构(4),更包括一相对于该张力滚轮(41)、轴接于该绕线系统面板(1)另一侧面,并能带动该张力滚轮(41)的马达(45);及 According to the winding system of the above-mentioned wire cutting machine, the wire clamping mechanism (4) further includes a shaft connected to the other side of the winding system panel (1) relative to the tension roller (41), And can drive the motor (45) of this tension roller (41); And
一设于该张力滚轮(41)远离致动装置(2)侧处,并与该张力滚轮(41)相接、以供夹持线极(W)用的定位滚轮(46)。 A positioning roller (46) arranged at the side of the tension roller (41) away from the actuator (2) and connected to the tension roller (41) for clamping the wire pole (W). the
根据上述的线切割加工机之绕线系统,所述传感器装置(5)是由一设于该绕线系统面板(1)与致动装置(2)同侧面处,并位于致动装置(2)与线极夹持机构(4)之间,能回授一讯号给致动装置(2)的角度传感器(51);及 According to the winding system of the above-mentioned wire cutting machine, the sensor device (5) is formed by a device located on the same side of the winding system panel (1) and the actuating device (2), and is located at the actuating device (2). ) and the wire clamping mechanism (4), a signal can be fed back to the angle sensor (51) of the actuating device (2); and
一支一端与该角度传感器(51)垂直连接、另端位于线极(W)之上方侧,并与该线极(W)相接触,可以感测线极(W)之上、下位置,且能带动该角度传感器(51)、以使角度传感器(51)能回授一讯号给致动装置(2)的探棒(52)所组成; One end is vertically connected to the angle sensor (51), and the other end is located on the upper side of the wire pole (W), and is in contact with the wire pole (W), so that the upper and lower positions of the wire pole (W) can be sensed, And it can drive the angle sensor (51), so that the angle sensor (51) can feed back a signal to the probe (52) of the actuator (2);
而所述绕线系统面板(1)相对于该探棒(52)处,更设有一能供探棒(52)上、下偏转角度的第二开槽(12)。 The winding system panel (1) is further provided with a second slot (12) for the upward and downward deflection angle of the probe (52) relative to the probe (52). the
根据上述的线切割加工机之绕线系统,所述传感器装置(5)是由一设于该绕线系统面板(1)与致动装置(2)同侧面处,并位于致动装置(2)与线极夹持机构(4)之间、垂直状设置、呈ㄇ形的滑轨架(53); According to the winding system of the above-mentioned wire cutting machine, the sensor device (5) is formed by a device located on the same side of the winding system panel (1) and the actuating device (2), and is located at the actuating device (2). ) and the wire pole clamping mechanism (4), vertically arranged, ㄇ-shaped slide rail frame (53);
两支设于该滑轨架(53)内,呈上、下相对状的固定支架(54); Two are arranged in this slide rail frame (53), are the fixed support (54) of upper and lower relative shape;
一设于该两固定支架(54)之间最底端、并与该线极(W)相接触,且能带动该固定支架(54)位移的滑轮(55); A pulley (55) located at the bottom end between the two fixed brackets (54), in contact with the wire pole (W), and capable of driving the displacement of the fixed brackets (54);
数个设于该两固定支架(54)之间两侧,能在滑轨架(53)间滑动的滚轮(56);及 Several rollers (56) that can slide between the slide rail frames (53) are located on both sides between the two fixed brackets (54); and
一设于该滑轨架(53)内一端,能感测固定支架(54)之上、下位置,能回授一讯号给致动装置(2)的位移传感器(57)所组成。 One is located at one end in the slide rail frame (53), can sense the upper and lower positions of the fixed support (54), and can feed back a signal to the displacement sensor (57) of the actuating device (2). the
根据上述的线切割加工机之绕线系统,所述煞车块(42)是由一弹性材料所制成。 According to the winding system of the above-mentioned wire cutting machine, the brake block (42) is made of an elastic material. the
根据上述的线切割加工机之绕线系统,所述致动器(44)是为下列之一:气压缸、液压缸、齿条驱动装置、齿轮驱动装置、飞轮驱动装置、曲柄驱动装置。 According to the winding system of the above-mentioned wire cutting machine, the actuator (44) is one of the following: pneumatic cylinder, hydraulic cylinder, rack driving device, gear driving device, flywheel driving device, crank driving device. the
根据上述的线切割加工机之绕线系统,所述马达(45)是为下列之一:转距马达、VR式步进马达。 According to the winding system of the above wire cutting machine, the motor (45) is one of the following: a torque motor, a VR type stepping motor. the
根据上述的线切割加工机之绕线系统,所述致动装置(2)内,更设有一能与该传感器装置(5)电连接,能处理该传感器装置(5)所回授之讯号、以调整致动装置(2)转速之快慢的DSP控制器。 According to the winding system of the above-mentioned wire cutting machine, the actuating device (2) is further provided with a device that can be electrically connected to the sensor device (5), and can process the signal fed back by the sensor device (5), A DSP controller for adjusting the speed of the rotating speed of the actuating device (2). the
为解决前述问题及达到本发明的目的,本发明技术手段,在方法方面,为一种如请求项1所述的线切割加工机之绕线系统的供线方法,其特征在于,包括步骤:
In order to solve the aforementioned problems and achieve the purpose of the present invention, the technical means of the present invention, in terms of methods, is a wire supply method for a wire winding system of a wire cutting machine as described in
步骤一:当该线切割加工机之绕线系统运作时,致动装置(2)将带动供线轮(3)旋转,使线极(W)由供线轮(3)依序经过传感器装置(5)、线极夹持机构(4)至惰轮(6)后输出; Step 1: When the wire winding system of the wire cutting machine is in operation, the actuating device (2) will drive the wire supply wheel (3) to rotate, so that the wire pole (W) passes the sensor device sequentially from the wire supply wheel (3) (5), output from the wire clamping mechanism (4) to the idler wheel (6);
步骤二:此时,传感器装置(5)将感测该线极(W)之上、下位置,并回授一 讯号给致动装置(2),以调整转速之快慢,使供线轮(3)至线极夹持机构(4)间的线极(W),呈现一松弛状态。 Step 2: At this time, the sensor device (5) will sense the upper and lower positions of the wire pole (W), and feed back a signal to the actuator device (2) to adjust the speed of the rotation speed, so that the wire supply wheel ( 3) The wire (W) between the wire clamping mechanism (4) is in a relaxed state. the
本发明可获以下几点优点: The present invention can obtain the following advantages:
1.本发明中,此种线切割加工机之绕线系统,以供线轮(3)主动旋转送线的方式,降低供线轮(3)的转动惯量,线极(W)无需拉紧带动供线轮(3),使线切割加工机之绕线系统能以低张力进行加工,可以避免张力过大而断线的问题,并且免除细线极拉动供线轮(3),其细线极产生拉伸而有低频扰动之问题的疑虑,进而达到加工稳定性与加工质量提升。 1. In the present invention, the wire winding system of this wire cutting processing machine uses the wire feeding wheel (3) to actively rotate and feed the wire to reduce the moment of inertia of the wire feeding wheel (3), and the wire pole (W) does not need to be tightened Drive the wire supply wheel (3), so that the wire winding system of the wire cutting machine can process with low tension, which can avoid the problem of thread breakage due to excessive tension, and avoid pulling the wire supply wheel (3) for thin wires. There may be doubts about low-frequency disturbance caused by stretching of the wire electrode, thereby achieving processing stability and improving processing quality. the
2.本发明中,透过传感器装置(5)的使用,能感测线极(W)的松弛状态,感测线极(W)之上、下位置,以回授一讯号给致动装置(2),让致动装置(2)可以调整其转速快、慢,让位线夹持机构(4)前段的线极(W)松弛,而配合线夹持机构(4)的使用后,更能使线夹持机构(4)前段的线极(W)松弛而不脱落,让线夹持机构(4)后段的线极(W),产生足够的张力,达到能以低张力运作加工、且使线极(W)之线张力更稳定的目的。 2. In the present invention, through the use of the sensor device (5), the relaxation state of the wire electrode (W) can be sensed, the upper and lower positions of the wire electrode (W) can be sensed, and a signal can be fed back to the actuator device (2), let the actuating device (2) adjust its rotating speed fast and slow, let the wire pole (W) in the front section of the wire clamping mechanism (4) relax, and cooperate with the use of the wire clamping mechanism (4), It can also make the wire pole (W) in the front section of the wire clamping mechanism (4) loose and not fall off, and allow the wire pole (W) in the rear section of the wire clamping mechanism (4) to generate enough tension to operate with low tension The purpose of processing and making the wire tension of the wire pole (W) more stable. the
附图说明 Description of drawings
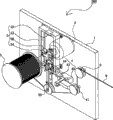
图1:本发明第一实施例有线极时的立体示意图。 Fig. 1: A three-dimensional schematic view of the first embodiment of the present invention when there are wired electrodes. the
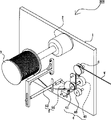
图2:本发明第二实施例有线极时的立体示意图。 Fig. 2: A three-dimensional schematic view of the second embodiment of the present invention when there are wired electrodes. the
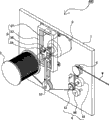
图3:本发明第三实施例有线极时的立体示意图。 Fig. 3: A three-dimensional schematic view of the third embodiment of the present invention when there are wired electrodes. the
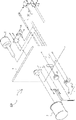
图4:本发明第四实施例有线极时的立体示意图。 Fig. 4: A three-dimensional schematic view of the fourth embodiment of the present invention when there are wired electrodes. the
图5:本发明第一实施例的立体分解示意图。 Fig. 5: An exploded perspective view of the first embodiment of the present invention. the
图6:本发明第二实施例的立体分解示意图。 Fig. 6: An exploded perspective view of the second embodiment of the present invention. the
图7:本发明第三实施例的立体分解示意图。 Fig. 7: An exploded perspective view of the third embodiment of the present invention. the
图8:本发明第四实施例的立体分解示意图。 Fig. 8: An exploded perspective view of the fourth embodiment of the present invention. the
图9:本发明的实施方块示意图。 Figure 9: A schematic block diagram of an embodiment of the present invention. the
组件符号: Component symbol:
1 绕线系统面板 1 Winding system panel
11 第一开槽 11 First slotting
12 第二开槽 12 Second slot
2 致动装置 2 Actuating device
3 供线轮 3 supply wheel
4 线夹持机构 4 wire clamping mechanism
41 张力滚轮 41 tension roller
42 煞车块 42 brake block
43 滑动支架 43 sliding bracket
44 致动器 44 Actuator
45 马达 45 motor
46 定位滚轮 46 positioning roller
5 感测装置 5 Sensing device
51 角度传感器 51 angle sensor
52 探棒 52 probe
53 滑轨架 53 Rail rack
54 固定支架 54 Fixed bracket
55 滚轮 55 Roller
56 滑轮 56 pulley
57 位移传感器 57 Displacement sensor
6 惰轮 6 idler wheel
W 线极 W line pole
A 当该线切割加工机之绕线系统运作时,致动装置(2)将带动供线轮 A When the wire winding system of the wire cutting machine is in operation, the actuating device (2) will drive the wire supply wheel
(3)旋转,使线极(W)由供线轮(3)依序经过传感器装置(5)、线极夹 (3) Rotate so that the wire pole (W) passes through the sensor device (5) and the wire pole clamp sequentially from the wire supply wheel (3)
持机构(4)至惰轮(6)后输出 Output from the holding mechanism (4) to the idler wheel (6)
B 此时,传感器装置(5)将感测该线极(W)之上、下位置,并回授一讯 B At this time, the sensor device (5) will sense the upper and lower positions of the wire (W) and give back a signal
号给致动装置(2),以调整转速之快慢,使供线轮(3)至线极夹持机 The number is given to the actuating device (2) to adjust the speed of the rotating speed so that the wire supply wheel (3) reaches the wire pole clamping machine
构(4)间的线极(W),呈现一松弛状态 The wire pole (W) between the structures (4) presents a relaxed state.
100 线切割加工机之绕线系统 100 Winding system of wire cutting machine
200 线切割加工机之绕线系统 200 Winding system of wire cutting machine
300 线切割加工机之绕线系统 300 Winding system of wire cutting machine
400 线切割加工机之绕线系统 400 Winding system for wire cutting machine
具体实施方式 Detailed ways
为了更具体呈现本发明的内容,以下参考图式,针对本发明的实施型态作详细说明。 In order to present the content of the present invention more specifically, the implementation forms of the present invention will be described in detail below with reference to the drawings. the
如图1所示为本发明第一实施例有线极时的立体示意图,如图2所示为本发明第二实施例有线极时的立体示意图,如图3所示为本发明第三实施例有线极时的立体示意图,如图4所示为本发明第四实施例有线极时的立体示意图,如图5所示为本发明第一实施例的立体分解示意图,如图6所示为本发明第二 实施例的立体分解示意图,如图7所示为本发明第三实施例的立体分解示意图,如图8所示为本发明第四实施例的立体分解示意图。 As shown in Figure 1, it is a three-dimensional schematic view of the first embodiment of the present invention when there are wired electrodes, and Figure 2 is a three-dimensional schematic view of the second embodiment of the present invention when there are wired electrodes, and Figure 3 is a schematic three-dimensional view of the third embodiment of the present invention The three-dimensional schematic diagram when there are wired poles, as shown in Figure 4, is the three-dimensional schematic diagram when the fourth embodiment of the present invention is wired, and Figure 5 is the three-dimensional exploded schematic diagram of the first embodiment of the present invention, as shown in Figure 6. The three-dimensional exploded schematic diagram of the second embodiment of the invention, as shown in Figure 7 is the three-dimensional exploded schematic diagram of the third embodiment of the present invention, and Figure 8 is the three-dimensional exploded schematic diagram of the fourth embodiment of the present invention. the
图式中揭示出,为一种线切割加工机之绕线系统,其特征在于包括: It is disclosed in the drawing that it is a winding system of a wire cutting machine, which is characterized by including:
一能与线切割加工机连接的绕线系统面板(1); A winding system panel (1) capable of being connected to the wire cutting machine;
一设于该绕线系统面板(1)一侧的致动装置(2); An actuating device (2) located on one side of the winding system panel (1);
一相对于该致动装置(2)、轴接于该绕线系统面板(1)另一侧面,并能被该致动装置(2)带动,以供输出一能让线切割加工机所使用之线极(W)的供线轮(3); One is connected to the other side of the winding system panel (1) relative to the actuating device (2), and can be driven by the actuating device (2) for output; one can be used by a wire cutting machine The wire supply wheel (3) of the wire pole (W);
一设于该绕线系统面板(1)、与供线轮(3)同侧之线极(W)输出端处,并具有一轴线与该供线轮(3)轴线平行之张力滚轮(41),能调整张力滚轮(41)松紧程度、以使后段线极(W)产生张力的线极夹持机构(4); One is located at the output end of the wire pole (W) on the same side of the winding system panel (1) as the wire supply wheel (3), and has a tension roller (41) whose axis is parallel to the axis of the wire supply wheel (3) ), which can adjust the tightness of the tension roller (41) so that the rear section of the wire (W) can generate tension for the wire pole clamping mechanism (4);
一设于致动装置(2)与线极夹持机构(4)之间,能感测线极(W)之上、下位置,并回授一讯号给致动装置(2),让致动装置(2)可以调整其转速快、慢的传感器装置(5);以及 One is located between the actuating device (2) and the wire clamping mechanism (4), which can sense the upper and lower positions of the wire (W), and feed back a signal to the actuating device (2), so that the The moving device (2) can adjust the fast and slow sensor device (5) of its rotating speed; and
至少一设于线极夹持机构(4)远离致动装置(2)侧处,能将线极夹持机构(4)所导出之线极(W)转向的惰轮(6)。 At least one idler wheel (6) is provided on the side of the wire clamping mechanism (4) away from the actuator (2), capable of turning the wire (W) led out by the wire clamping mechanism (4). the
其中,致动装置(2)能带动供线轮(3)旋转,使供线轮(3)与线夹持机构(4)间之线极(W)呈现松弛状态,其传感器装置(5)感测线极(W)的松弛状态,线夹持机构(4)能使线极(W)松弛而不脱落。 Among them, the actuating device (2) can drive the wire supply wheel (3) to rotate, so that the wire pole (W) between the wire supply wheel (3) and the wire clamping mechanism (4) presents a relaxed state, and its sensor device (5) Sensing the slack state of the wire pole (W), the wire clamping mechanism (4) can make the wire pole (W) loose without falling off. the
其次,藉由线极夹持机构(4)的使用,控制线极夹持机构(4)松紧度,以产生一足够的摩擦力,使线极(W)靠近供线轮(3)的一端[前段],保持在松弛状态下,而另一端[后段]保持在紧绷状态下,使位于线极夹持机构(4)另一端[后段]的线极(W),产生一张力而得以用于加工。 Secondly, by using the wire pole clamping mechanism (4), control the tightness of the wire pole clamping mechanism (4), so as to generate a sufficient friction force, so that the wire pole (W) is close to one end of the wire supply wheel (3) [Front section] is kept in a relaxed state, while the other end [Rear section] is kept in a tight state, so that the wire (W) at the other end [Rear section] of the wire clamping mechanism (4) generates a tension and be used for processing. the
再者,透过供线轮(3)配合致动装置(2),主动旋转送线的方式,降低供线轮(3)转动惯量,线极(W)无需拉紧带动供线轮(3),配合前述的线极夹持机构(4)和传感器装置(5),让使用本发明的微线极之线切割加工机,可以利用低张力进行加工,能避免张力过大而断线的问题,并且免除细线拉动供线轮,使细线拉伸而产生低频扰动之问题,并以此方式将供线轮(3)转动惯量降低及/或隔绝,让本发明达到能以低张力运作加工、且使线极(W)之线张力更稳定的目的,进而达到高加工稳定性与提升加工质量的目标。 Furthermore, through the way that the wire supply wheel (3) cooperates with the actuating device (2) to actively rotate and feed the wire, the moment of inertia of the wire supply wheel (3) is reduced, and the wire pole (W) does not need to be tightened to drive the wire supply wheel (3 ), in conjunction with the aforementioned wire pole clamping mechanism (4) and sensor device (5), the wire cutting machine of the micro wire pole of the present invention can be processed with low tension, and can avoid excessive tension and wire breakage problem, and avoid the problem that the thin wire pulls the wire supply wheel, which causes the thin wire to stretch and produce low-frequency disturbances, and in this way reduces and/or isolates the moment of inertia of the wire supply wheel (3), so that the present invention can achieve low tension The purpose of operating the processing and making the wire tension of the wire electrode (W) more stable, and then achieving the goal of high processing stability and improving processing quality. the
上述中,所述线极夹持机构(4),更包括一设于该张力滚轮(41)接近致动装置(2)侧处,并与该张力滚轮(41)相接触,能对张力滚轮(41)加压、以调整张力滚轮(41)松紧程度的煞车块(42); In the above, the wire pole clamping mechanism (4) further includes a device located at the side of the tension roller (41) close to the actuating device (2) and in contact with the tension roller (41). (41) pressurize, to adjust the brake block (42) of tension roller (41) degree of tightness;
一设于该煞车块(42)不与张力滚轮(41)相接触之端处,能带动煞车块(42)移动位移、以对张力滚轮(41)加压的滑动支架(43);及 One is located at the end of the brake block (42) not in contact with the tension roller (41), which can drive the brake block (42) to move and displace, so as to pressurize the tension roller (41) sliding bracket (43); and
一与该滑动支架(43)连接,能带动滑动支架(43)移动位移的致动器(44); One is connected with this sliding support (43), can drive the actuator (44) of sliding support (43) mobile displacement;
而所述绕线系统面板(1)相对于该滑动支架(43)处,更设有一能供滑动支架(43)定位与滑移的第一开槽(11)。 The winding system panel (1) is further provided with a first slot (11) for positioning and sliding of the sliding bracket (43) relative to the sliding bracket (43). the
其中,透过此种配置,能快速达到控制张力滚轮(41)的效果,但不精确,适用于一般精度的微线极之线切割加工机使用,能大幅度的降低成本。 Among them, through this configuration, the effect of controlling the tension roller (41) can be quickly achieved, but it is not precise, and it is suitable for use in a micro-wire cutting machine with general precision, and can greatly reduce the cost. the
上述中,所述线极夹持机构(4),更包括一相对于该张力滚轮(41)、轴接于该绕线系统面板(1)另一侧面,并能带动该张力滚轮(41)的马达(45);及 In the above, the wire clamping mechanism (4) further includes a shaft connected to the other side of the winding system panel (1) relative to the tension roller (41), and can drive the tension roller (41) motor (45); and
一设于该张力滚轮(41)远离致动装置(2)侧处,并与该张力滚轮(41)相接、以供夹持线极(W)用的定位滚轮(46)。 A positioning roller (46) arranged at the side of the tension roller (41) away from the actuator (2) and connected to the tension roller (41) for clamping the wire pole (W). the
其中,透过此种配置,能达到精确控制张力滚轮(41)的效果,适用于高精度的微线极之线切割加工机使用,而相较于现有的张力控制方式,成本更低,但更稳定。 Among them, through this configuration, the effect of precise control of the tension roller (41) can be achieved, which is suitable for use in high-precision micro-wire wire cutting machines, and compared with the existing tension control method, the cost is lower. But more stable. the
上述中,所述传感器装置(5)是由一设于该绕线系统面板(1)与致动装置(2)同侧面处,并位于致动装置(2)与线极夹持机构(4)之间,能回授一讯号给致动装置(2)的角度传感器(51);及 In the above, the sensor device (5) is provided on the same side of the winding system panel (1) and the actuating device (2), and is located between the actuating device (2) and the wire clamping mechanism (4). ), can feed back a signal to the angle sensor (51) of the actuating device (2); and
一支一端与该角度传感器(51)垂直连接、另端位于线极(W)之上方侧,并与该线极(W)相接触,可以感测线极(W)之上、下位置,且能带动该角度传感器(51)、以使角度传感器(51)能回授一讯号给致动装置(2)的探棒(52)所组成; One end is vertically connected to the angle sensor (51), and the other end is located on the upper side of the wire pole (W), and is in contact with the wire pole (W), so that the upper and lower positions of the wire pole (W) can be sensed, And it can drive the angle sensor (51), so that the angle sensor (51) can feed back a signal to the probe (52) of the actuator (2);
而所述绕线系统面板(1)相对于该探棒(52)处,更设有一能供探棒(52)上、下偏转角度的第二开槽(12)。 The winding system panel (1) is further provided with a second slot (12) for the upward and downward deflection angle of the probe (52) relative to the probe (52). the
其中,透过此种配置,能以探棒(52)直接感测线极(W)之上、下位置,且当探棒(52)被线极(W)带动,而角度产生变化时,同时能带动该角度传感器(51),以使角度传感器(51)产生感应,并回授一讯号给致动装置(2),以透过控制致动装置(2),达到控制供线轮(3)转动惯量与供线的效果,因为回传的是一角度变化量,所以需要多一道转换手续,故适用于不需要高速反应的微线极之线切割加工机使用。 Wherein, through this configuration, the probe (52) can directly sense the upper and lower positions of the wire (W), and when the probe (52) is driven by the wire (W) and the angle changes, Simultaneously, the angle sensor (51) can be driven so that the angle sensor (51) generates an induction, and a signal is fed back to the actuating device (2), so as to control the actuating device (2) to control the wire supply wheel ( 3) The moment of inertia and the effect of wire supply, because the return is an angle change, so an additional conversion procedure is required, so it is suitable for use in micro-wire cutting machines that do not require high-speed response. the
上述中,所述传感器装置(5)是由一设于该绕线系统面板(1)与致动装置(2)同侧面处,并位于致动装置(2)与线极夹持机构(4)之间、垂直状设置、呈ㄇ形的滑轨架(53); In the above, the sensor device (5) consists of a device located on the same side of the winding system panel (1) and the actuating device (2), and is located between the actuating device (2) and the wire clamping mechanism (4). ), set vertically, and be a ㄇ-shaped slide rail frame (53);
两支设于该滑轨架(53)内,呈上、下相对状的固定支架(54); Two are arranged in this slide rail frame (53), are the fixed support (54) of upper and lower relative shape;
一设于该两固定支架(54)之间最底端、并与该线极(W)相接触,且能带动该固定支架(54)位移的滑轮(55); A pulley (55) located at the bottom end between the two fixed brackets (54), in contact with the wire pole (W), and capable of driving the displacement of the fixed brackets (54);
数个设于该两固定支架(54)之间两侧,能在滑轨架(53)间滑动的滚轮(56);及 Several rollers (56) that can slide between the slide rail frames (53) are located on both sides between the two fixed brackets (54); and
一设于该滑轨架(53)内一端,能感测固定支架(54)之上、下位置,能回授一讯号给致动装置(2)的位移传感器(57)所组成。 One is located at one end in the slide rail frame (53), can sense the upper and lower positions of the fixed support (54), and can feed back a signal to the displacement sensor (57) of the actuating device (2). the
其中,当滑轮(55)移动时,因为此装置的滑动特点,位移传感器(57)能感测固定支架(54)之上、下位置,以回授一讯号给致动装置(2),以透过控制致动装置(2),达到控制供线轮(3)转动惯量与供线的效果,因为回传的是线极(W)的上、下移动量,非前述的角度变化,不需要多一道转换手续,故能提高整体的反应速率,适用于需要中、高速反应的微线极之线切割加工机使用。 Wherein, when the pulley (55) moves, because of the sliding feature of this device, the displacement sensor (57) can sense the upper and lower positions of the fixed bracket (54), and feed back a signal to the actuating device (2) to By controlling the actuating device (2), the effect of controlling the moment of inertia of the wire supply wheel (3) and the wire supply is achieved, because what is returned is the up and down movement of the wire pole (W), not the aforementioned angle change, not the An additional conversion procedure is required, so the overall reaction rate can be improved, and it is suitable for use in wire cutting machines for micro-wire electrodes that require medium and high-speed reactions. the
上述中,所述煞车块(42)是由一弹性材料所制成。 In the above, the brake block (42) is made of an elastic material. the
其中,透过弹性材料的使用,当对张力滚轮(41)接触挤压时,能产生一磨擦力,并能避免对张力滚轮(41)产生伤害,同时达到张力滚轮(41)煞车的效果,藉此控制线极(W)其张力的大小。 Wherein, through the use of elastic material, when the tension roller (41) is contacted and squeezed, a frictional force can be generated, and damage to the tension roller (41) can be avoided, and at the same time, the effect of braking the tension roller (41) can be achieved. In this way, the tension of the wire (W) can be controlled. the
上述中,所述致动器(44)是为下列之一:气压缸、液压缸、齿条驱动装置、齿轮驱动装置、飞轮驱动装置、曲柄驱动装置。 Among the above, the actuator (44) is one of the following: a pneumatic cylinder, a hydraulic cylinder, a rack drive, a gear drive, a flywheel drive, and a crank drive. the
其中,透过不同的致动器(44)的应用,能提供使用者不同的选择,以符合使用者之线切割加工机的需求。 Among them, through the application of different actuators (44), different options can be provided for the user to meet the needs of the user's wire cutting machine. the
上述中,所述马达(45)是为下列之一:转距马达、VR式步进马达。 Among the above, the motor (45) is one of the following: torque motor, VR type stepping motor. the
其中,只要能控制张力滚轮(41)的转动,以对线极(W)产生一张力控制的效果,就能做为本发明中的马达(45)使用,并不局限与上述的两种。 Wherein, as long as the rotation of the tension roller (41) can be controlled to produce a tension control effect on the wire pole (W), it can be used as the motor (45) in the present invention, and is not limited to the above two types. the
其次,透过不同马达(45)的应用,能提供使用者不同的选择,以符合使用者的需求。 Secondly, through the application of different motors (45), different options can be provided for the user to meet the needs of the user. the
上述中,所述致动装置(2)内,更设有一能与该传感器装置(5)电连接,能处理该传感器装置(5)所回授之讯号、以调整致动装置(2)转速之快慢的DSP[DigitalSignal Processing]控制器。 In the above, the actuating device (2) is further provided with a motor that can be electrically connected to the sensor device (5), and can process the signal fed back by the sensor device (5) to adjust the rotation speed of the actuating device (2). The fast and slow DSP[DigitalSignal Processing] controller. the
其中,透过此种设置方式,以达到精确、快速控制致动装置(2)转速的效果,能避免因为转速变动过慢或误差过大,而让线极(W)的张力异常,产生种种的加工问题,而让加工成本上升。 Among them, through this setting method, the effect of precise and rapid control of the rotation speed of the actuating device (2) can be achieved, which can avoid the abnormal tension of the wire electrode (W) due to the slow change of the rotation speed or excessive error, and various The processing problem, and let the processing cost rise. the
另一方面,透过上述两种线极夹持机构(4)与两种传感器装置(5)的配合,能形成四种实施型态: On the other hand, through the cooperation of the above two kinds of wire clamping mechanisms (4) and the two kinds of sensor devices (5), four implementation types can be formed:
[1]第一实施例,如图1与图5所示的线切割加工机之绕线系统(100),适用于一般精度、一般反应速度的微线极之线切割加工机。 [1] The first embodiment, the winding system (100) of the wire cutting machine shown in Figure 1 and Figure 5, is suitable for wire cutting machines with general precision and general response speed. the
[2]第二实施例,如图2与图6所示的线切割加工机之绕线系统(200),适用于一般精度、中反应速度的微线极之线切割加工机。 [2] The second embodiment, the winding system (200) of the wire cutting machine as shown in Fig. 2 and Fig. 6, is suitable for the wire cutting machine of micro wire cutting machine with general precision and medium response speed. the
[3]第三实施例,如图3与图7所示的线切割加工机之绕线系统(300),适用于中精度、一般反应速度的微线极之线切割加工机。 [3] The third embodiment, the wire-cutting machine winding system (300) shown in FIG. 3 and FIG. 7 is suitable for wire-cutting machines with medium precision and general response speed. the
[4]第四实施例,如图4与图8所示的线切割加工机之绕线系统(400),适用于高精度、高反应速度的微线极之线切割加工机。 [4] The fourth embodiment, the winding system ( 400 ) of the wire cutting machine shown in FIG. 4 and FIG. 8 is suitable for a wire cutting machine with high precision and high response speed. the
透过不同的配合,能适用于众多不同需求的微线极之线切割加工机。 Through different cooperation, it can be applied to many micro-wire wire cutting machines with different needs. the
最后应说明的是,本发明所提及的两种线极夹持机构(4)与两种传感器装置(5),为本发明的较佳实施例,实际应用时,应依线切割加工机、线极、及被加工材料的状态,进行变动,但线极夹持机构(4)与传感器装置(5)的结构众多,故不于此详加叙述。 Finally, it should be noted that the two wire clamping mechanisms (4) and the two sensor devices (5) mentioned in the present invention are preferred embodiments of the present invention. , the wire, and the state of the processed material change, but there are many structures of the wire clamping mechanism (4) and the sensor device (5), so they will not be described in detail here. the
如图9所示为本发明的实施方块示意图。图式中揭示出,为一种如请求项1所述的线切割加工机之绕线系统的供线方法,其特征在于,包括步骤:
Figure 9 is a schematic diagram of an embodiment of the present invention. It is disclosed in the drawings that it is a wire supply method for the winding system of the wire cutting machine as described in
步骤一:当该线切割加工机之绕线系统运作时,致动装置(2)将带动供线轮(3)旋转,使线极(W)由供线轮(3)依序经过传感器装置(5)、线极夹持机构(4)至惰轮(6)后输出(A); Step 1: When the wire winding system of the wire cutting machine is in operation, the actuating device (2) will drive the wire supply wheel (3) to rotate, so that the wire pole (W) passes the sensor device sequentially from the wire supply wheel (3) (5), output (A) from the wire pole clamping mechanism (4) to the idler wheel (6);
步骤二:此时,传感器装置(5)将感测该线极(W)之上、下位置,并回授一讯号给致动装置(2),以调整转速之快慢,使供线轮(3)至线极夹持机构(4)间的线极(W),呈现一松弛状态(B)。 Step 2: At this time, the sensor device (5) will sense the upper and lower positions of the wire pole (W), and feed back a signal to the actuator device (2) to adjust the speed of the rotation speed, so that the wire supply wheel ( 3) The wire (W) between the wire clamping mechanism (4) presents a relaxed state (B). the
其中,透过此种供线方法的应用,能让本发明的线切割加工机之绕线系统,发挥出应有的功能,让线切割加工机之绕线系统能正常的运作及被使用。 Wherein, through the application of this wire supply method, the wire winding system of the wire cutting machine of the present invention can play its due function, so that the wire winding system of the wire cutting machine can operate normally and be used. the
由上述能得知,本发明中,透过致动装置(2)、供线轮(3)、线极夹持机构(4)、及传感器装置(5)的配合应用,能达到将供线轮(3)转动惯量降低及/或隔绝,达到能以低张力运作加工、且使线张力更稳定的目的,相较于现今的传统微线极之线切割加工机的绕线系统,更具有实用性、功效性与产业利用性。 From the above, it can be seen that in the present invention, through the cooperative application of the actuator device (2), the wire supply wheel (3), the wire electrode clamping mechanism (4), and the sensor device (5), the wire supply can be achieved. The moment of inertia of the wheel (3) is reduced and/or isolated to achieve the purpose of processing with low tension and making the wire tension more stable. Compared with the winding system of today's traditional micro-wire wire cutting machine, it has more Practicality, efficacy and industrial applicability. the
最后应说明的是:以上实施例仅用以说明本发明,而非限制本发明所描述的技术方案;因此,尽管本说明书参照上述的各个实施例,对本发明已进行了详细的说明,但是,本领域的普通技术人员应当理解,仍然可以对本发明进行修改或等同替换;因此举凡与本发明意旨相符的修饰性变化,只要在均等范围内,都应涵属于本发明专利范围内。 Finally, it should be noted that: the above embodiments are only used to illustrate the present invention, rather than limit the technical solution described in the present invention; therefore, although the specification has described the present invention in detail with reference to the above-mentioned various embodiments, but, Those of ordinary skill in the art should understand that the present invention can still be modified or equivalently replaced; therefore, any modification that is in line with the intent of the present invention should fall within the patent scope of the present invention as long as it is within the scope of equality. the
Claims (10)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201010158106 CN102233463B (en) | 2010-04-27 | 2010-04-27 | Wire winding system and wire supply method for wire cutting machine |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN 201010158106 CN102233463B (en) | 2010-04-27 | 2010-04-27 | Wire winding system and wire supply method for wire cutting machine |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN102233463A true CN102233463A (en) | 2011-11-09 |
| CN102233463B CN102233463B (en) | 2013-02-20 |
Family
ID=44884849
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN 201010158106 Expired - Fee Related CN102233463B (en) | 2010-04-27 | 2010-04-27 | Wire winding system and wire supply method for wire cutting machine |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN102233463B (en) |
Cited By (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103418870A (en) * | 2013-08-22 | 2013-12-04 | 苏州新火花机床有限公司 | Double-wire-tube wire travelling mechanism in lead screw connecting rod movement wire discharge mode |
| CN105084113A (en) * | 2015-06-26 | 2015-11-25 | 北京天地玛珂电液控制系统有限公司 | Automatic wire winding device |
| CN108933405A (en) * | 2017-05-24 | 2018-12-04 | 丁明远 | Electric wire wire bundling device |
| TWI643688B (en) * | 2018-03-30 | 2018-12-11 | National Taiwan Normal University | Fluid-controlled wire tension mechanism |
| CN109967806A (en) * | 2017-12-28 | 2019-07-05 | 发那科株式会社 | The automatic connection method of wire electric discharge machine and wire electric discharge machine |
| CN110254854A (en) * | 2019-07-26 | 2019-09-20 | 吉林大学 | Automatic winding device |
| CN111151513A (en) * | 2018-11-07 | 2020-05-15 | 北京石墨烯研究院 | Belt-shaped article cleaning device and cleaning method |
| US20210151223A1 (en) * | 2014-03-21 | 2021-05-20 | Quanta Associates, Lp | Method and apparatus for continuously processing conductor cable for disposal or recycling |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5914428A (en) * | 1982-07-08 | 1984-01-25 | Makino Milling Mach Co Ltd | Wire electrode winding guide device for wire cut electrical discharge machine |
| JPS6464724A (en) * | 1987-09-07 | 1989-03-10 | Matsushita Electric Industrial Co Ltd | Traveling device for fine electric discharge wire |
| JPH06329336A (en) * | 1991-11-29 | 1994-11-29 | Niigata Eng Co Ltd | Brake device of wire deliver device |
| CN1876301A (en) * | 2006-07-06 | 2006-12-13 | 上海交通大学 | Horizontally wire-feeding split type micro electric spark wire cutting device |
| CN101045262A (en) * | 2006-03-30 | 2007-10-03 | 发那科株式会社 | Wire electrode supply device for wire-cut electric discharge machine |
| CN101121212A (en) * | 2007-09-06 | 2008-02-13 | 钟树平 | Automatic screwing device for electric sparkle wire cutting machine and electric sparkle wire cutting machine |
-
2010
- 2010-04-27 CN CN 201010158106 patent/CN102233463B/en not_active Expired - Fee Related
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5914428A (en) * | 1982-07-08 | 1984-01-25 | Makino Milling Mach Co Ltd | Wire electrode winding guide device for wire cut electrical discharge machine |
| JPS6464724A (en) * | 1987-09-07 | 1989-03-10 | Matsushita Electric Industrial Co Ltd | Traveling device for fine electric discharge wire |
| JPH06329336A (en) * | 1991-11-29 | 1994-11-29 | Niigata Eng Co Ltd | Brake device of wire deliver device |
| CN101045262A (en) * | 2006-03-30 | 2007-10-03 | 发那科株式会社 | Wire electrode supply device for wire-cut electric discharge machine |
| CN1876301A (en) * | 2006-07-06 | 2006-12-13 | 上海交通大学 | Horizontally wire-feeding split type micro electric spark wire cutting device |
| CN101121212A (en) * | 2007-09-06 | 2008-02-13 | 钟树平 | Automatic screwing device for electric sparkle wire cutting machine and electric sparkle wire cutting machine |
Cited By (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103418870A (en) * | 2013-08-22 | 2013-12-04 | 苏州新火花机床有限公司 | Double-wire-tube wire travelling mechanism in lead screw connecting rod movement wire discharge mode |
| CN103418870B (en) * | 2013-08-22 | 2016-01-20 | 苏州新火花机床有限公司 | A kind of mariages cylinder wire feeder of leading screw link motion row silk mode |
| US20210151223A1 (en) * | 2014-03-21 | 2021-05-20 | Quanta Associates, Lp | Method and apparatus for continuously processing conductor cable for disposal or recycling |
| CN105084113A (en) * | 2015-06-26 | 2015-11-25 | 北京天地玛珂电液控制系统有限公司 | Automatic wire winding device |
| CN108933405A (en) * | 2017-05-24 | 2018-12-04 | 丁明远 | Electric wire wire bundling device |
| CN109967806A (en) * | 2017-12-28 | 2019-07-05 | 发那科株式会社 | The automatic connection method of wire electric discharge machine and wire electric discharge machine |
| US10974331B2 (en) | 2017-12-28 | 2021-04-13 | Fanuc Corporation | Wire electrical discharge machine and auto wire feeding method of wire electrical discharge machine |
| CN109967806B (en) * | 2017-12-28 | 2021-05-04 | 发那科株式会社 | Wire electric discharge machine and automatic wire connection method for wire electric discharge machine |
| TWI643688B (en) * | 2018-03-30 | 2018-12-11 | National Taiwan Normal University | Fluid-controlled wire tension mechanism |
| CN111151513A (en) * | 2018-11-07 | 2020-05-15 | 北京石墨烯研究院 | Belt-shaped article cleaning device and cleaning method |
| CN110254854A (en) * | 2019-07-26 | 2019-09-20 | 吉林大学 | Automatic winding device |
Also Published As
| Publication number | Publication date |
|---|---|
| CN102233463B (en) | 2013-02-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN102233463B (en) | Wire winding system and wire supply method for wire cutting machine | |
| CN1165476C (en) | Wire winding device | |
| CN203150668U (en) | Coiling device | |
| CN102101325B (en) | Radial Balance Mechanism of Automatic Cable Arranging Device for Multi-wire Cutting Machine | |
| CN104036879B (en) | Concentric type Double Motor Control winding machine | |
| CN206711676U (en) | A kind of take-up of strand winder | |
| CN104418158A (en) | Device for precision winding of welding wire | |
| KR101511113B1 (en) | Device for controling tension and string winding machine using the device | |
| JP2012004319A (en) | Edge-wise wound coil manufacturing device | |
| KR100407765B1 (en) | Winding Apparatus | |
| CN106206002A (en) | A kind of superconducting magnet automatic coiling device | |
| CN102403121A (en) | A fully automatic reed coil winding machine | |
| CN206810868U (en) | A kind of cable wire drawing tensioning apparatus | |
| CN110240011A (en) | A shaft row type active pay-off machine with deviation correcting device | |
| CN117226677A (en) | Double-roller ultrasonic excitation silicon carbide wire cutting device capable of cutting in large size | |
| CN104319014B (en) | Take-up bus cable device for Production of Enamel Wires | |
| CN110767932B (en) | Clamping mechanism and diaphragm tail winding mechanism | |
| CN207771026U (en) | Carborundum line cuts after-combustion all-in-one machine | |
| CN215974297U (en) | Automatic pay-off speed adjusting device | |
| CN213707325U (en) | A rewinding machine with a new wire arrangement | |
| CN212503389U (en) | Flat cable intelligence winding arrangement machine | |
| CN120148972A (en) | Automatic wire twisting machine for industrial robot cables | |
| CN210710040U (en) | Electromagnetic wire pay-off rack | |
| CN103578659A (en) | Cable wrapping machine with tension insulation thickness electronically and automatically controlled | |
| TW201125702A (en) | Wire winding system for wire cut processing machine and wire supply method thereof |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| CF01 | Termination of patent right due to non-payment of annual fee | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20130220 Termination date: 20190427 |