CN101526007B - Underground coal bunker cleaning robot - Google Patents
Underground coal bunker cleaning robot Download PDFInfo
- Publication number
- CN101526007B CN101526007B CN2009100200115A CN200910020011A CN101526007B CN 101526007 B CN101526007 B CN 101526007B CN 2009100200115 A CN2009100200115 A CN 2009100200115A CN 200910020011 A CN200910020011 A CN 200910020011A CN 101526007 B CN101526007 B CN 101526007B
- Authority
- CN
- China
- Prior art keywords
- hydraulic cylinder
- coal bunker
- arm
- underground coal
- camera
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images

Landscapes
- Manipulator (AREA)
Abstract
本发明公开一种井下煤仓清仓机器人,包括:用于与仓外卷扬装置的牵引缆绳连接的悬吊机构;用于驱动下述上位机构与下位机构分别旋转摆动的驱动机构;用于支撑仓壁进行定位的上位机构,上位机构设置有至少两条能伸缩的横向支撑臂,横向支撑臂的自由端设置有带有尖状物的接触部;用于铲除仓壁凝结物的下位机构,下位机构设置有至少两条能伸缩的横向工作臂,横向工作臂的自由端设置能上下往复动作的煤铲;至少一只用于摄取仓壁现场情形的摄像头,摄像头与仓外监视器连接。操作者只要在仓外通过电控系统等对井下煤仓清仓机器人进行相应操作,即可完成整个井下煤仓立壁及其下缩口处的清洁任务,能够减少人力物力,实现井下清仓的机械化。
The invention discloses an underground coal bunker clearing robot, which includes: a suspension mechanism used to connect with the traction cable of the hoisting device outside the bunker; a driving mechanism used to drive the following upper mechanism and lower mechanism to rotate and swing respectively; The upper mechanism for positioning the warehouse wall, the upper mechanism is provided with at least two retractable lateral support arms, and the free end of the lateral support arms is provided with a contact portion with a pointed object; the lower mechanism for removing the condensation on the warehouse wall, The lower mechanism is provided with at least two telescopic horizontal working arms, and the free end of the horizontal working arms is provided with a coal shovel that can reciprocate up and down; at least one camera for capturing the scene of the warehouse wall, and the camera is connected with the monitor outside the warehouse. The operator only needs to operate the underground coal bunker cleaning robot through the electronic control system outside the warehouse, and can complete the cleaning task of the entire underground coal bunker vertical wall and the lower shrinkage, which can reduce manpower and material resources and realize the mechanization of underground coal bunker cleaning.
Description
技术领域technical field
本发明涉及一种用于井下煤仓(井下矸石仓)清理的清仓装置,特别涉及其中一种井下煤仓清仓机器人。The invention relates to a warehouse clearing device for cleaning underground coal bunkers (underground gangue bins), in particular to an underground coal bunker clearing robot.
背景技术Background technique
井下煤仓为用在煤矿井下的原煤储存装置,一般为上下缩口的筒状结构,上部结构为上缩口,底部结构为下缩口放煤口。在煤矿井下开采过程中,不断有新的原煤加入井下煤仓,同时仓内原煤通过放煤口流出到皮带运输机,由皮带运输机输送到立井提升机,把煤炭提升到地面煤仓,再由地面煤仓装入火车或汽车运输到国民经济的各行各业。井下煤仓经过长期使用,在煤仓壁面上便会凝结一定量的原煤凝结物。这些凝结物的存在,一方面导致煤流的阻滞,大大减少了井下煤仓的储存量;另一方面为防止煤仓凝结物掉落,为确保安全必须在清仓后才能对煤仓底部的破碎机、转载机等设备进行检修。这样必须定期人工对井下煤仓进行清仓,铲除煤壁凝结物。人工清仓不仅劳动效率低,而且煤尘危害施工人员;井下煤仓一般深达18~30米,仓内空气稀薄且十分昏暗,人工清洁煤壁除了劳动强度大外还存在严重的安全隐患。同样,井下矸石仓也要像井下煤仓一样需要定时进行清洁,清理难度比煤仓更大。现有技术中未见用于清理井下煤仓(矸石仓)仓壁的清仓装备(装置)。The underground coal bunker is a raw coal storage device used in coal mines. It is generally a cylindrical structure with upper and lower necks, the upper structure is an upper neck, and the bottom structure is a lower neck. During the underground mining process of coal mines, new raw coal is continuously added to the underground coal bunker. At the same time, the raw coal in the bunker flows out to the belt conveyor through the coal discharge port, and is transported by the belt conveyor to the vertical shaft hoist, and the coal is lifted to the ground coal bunker, and then discharged from the ground. Coal bunkers are loaded into trains or automobiles for transportation to all walks of life in the national economy. After long-term use of the underground coal bunker, a certain amount of raw coal condensation will condense on the wall of the coal bunker. The existence of these condensates, on the one hand, leads to the blockage of coal flow, which greatly reduces the storage capacity of the underground coal bunker; Crusher, loader and other equipment for maintenance. In this way, the underground coal bunker must be manually cleaned regularly to remove the coal wall condensate. Manual warehouse clearance is not only low labor efficiency, but also coal dust endangers construction workers; underground coal warehouses are generally 18-30 meters deep, and the air in the warehouse is thin and very dark. In addition to labor-intensive cleaning of coal walls, there are serious safety hazards. Similarly, underground gangue bins also need to be cleaned regularly like underground coal bunkers, which is more difficult to clean than coal bunkers. There is no clearing equipment (device) for cleaning the walls of underground coal bunkers (gangue bins) in the prior art.
发明内容Contents of the invention
本发明在于克服现有人工清仓技术存在的上述技术缺陷,提供一种井下煤仓清仓机器人,其机械构成部分能够满足清理井下煤仓(矸石仓)的需要。The present invention aims to overcome the above-mentioned technical defects in the existing manual cleaning technology, and provides an underground coal bunker cleaning robot, whose mechanical components can meet the needs of cleaning underground coal bunkers (gangue bins).
其技术解决方案是:Its technical solutions are:
一种井下煤仓清仓机器人,包括:An underground coal bunker clearing robot, comprising:
用于与仓外卷扬装置的牵引缆绳连接的悬吊机构;Suspension mechanism for connection with the traction cable of the hoisting device outside the warehouse;
用于驱动下述上位机构与下位机构分别旋转摆动的驱动机构;The driving mechanism used to drive the following upper mechanism and lower mechanism to rotate and swing respectively;
用于支撑仓壁进行定位的上位机构;上述上位机构设置有三条能伸缩的横向支撑臂,横向支撑臂的自由端设置有带有尖状物的接触部;An upper mechanism used to support the warehouse wall for positioning; the above-mentioned upper mechanism is provided with three telescopic horizontal support arms, and the free ends of the horizontal support arms are provided with contact parts with pointed objects;
用于铲除仓壁凝结物的下位机构;上述下位机构设置有两条能伸缩且对称布置的横向工作臂,横向工作臂的自由端设置能上下往复动作的煤铲;The lower mechanism used to remove the condensate on the warehouse wall; the lower mechanism is provided with two telescopic and symmetrically arranged transverse working arms, and the free end of the transverse working arm is provided with a coal shovel capable of reciprocating up and down;
至少一只用于摄取仓壁现场情形的摄像头,摄像头与仓外监视器连接。At least one camera is used to capture the situation on the warehouse wall, and the camera is connected to the monitor outside the warehouse.
上述三条横向支撑臂在周向上按120°均布,每条横向支撑臂包括可伸缩支撑臂主体及支撑臂液压缸,支撑臂主体采取由多节平行四边形铰接式单元组成的杆体结构,支撑臂液压缸的活塞杆端与首节铰接式单元中的某一适宜铰杆传动连接,支撑臂液压缸带动支撑臂主体伸长及回缩;上述每条横向工作臂包括可伸缩工作臂主体及工作臂液压缸,工作臂主体采取由多节平行四边形铰接式单元组成的杆体结构,工作臂液压缸的活塞杆端与首节铰接式单元的某一适宜铰杆传动连接,工作臂液压缸带动工作臂主体伸长及回缩;在横向工作臂的自由端设置有煤铲液压缸,煤铲固定联接在煤铲液压缸的活塞杆端;上述横向支撑臂与横向工作臂各设置有断开装置,该断开装置能使臂主体绕固定轴旋转并垂直放下。The above three horizontal support arms are evenly distributed at 120° in the circumferential direction. Each horizontal support arm includes a telescopic support arm body and a support arm hydraulic cylinder. The support arm body adopts a rod structure composed of multi-section parallelogram articulated units. The support arm The piston rod end of the hydraulic cylinder is connected to a suitable hinge rod in the first articulated unit, and the support arm hydraulic cylinder drives the main body of the support arm to extend and retract; each of the above-mentioned horizontal working arms includes a telescopic working arm main body and a working arm. Arm hydraulic cylinder, the main body of the working arm adopts a rod structure composed of multi-section parallelogram articulated units, the piston rod end of the working arm hydraulic cylinder is connected with a suitable hinge rod of the first articulated unit, and the working arm hydraulic cylinder drives the work The main body of the arm is extended and retracted; the free end of the horizontal working arm is provided with a coal shovel hydraulic cylinder, and the coal shovel is fixedly connected to the piston rod end of the coal shovel hydraulic cylinder; the above-mentioned horizontal support arm and the horizontal working arm are each equipped with a disconnecting device , the disconnecting device enables the arm body to rotate around a fixed axis and be lowered vertically.
上述摄像头包括第一位次上的摄像头和/或第二位次上的摄像头;第一位次上的摄像头设置在牵引缆绳上,第二位次上的摄像头固定在上位机构或下位机构的适宜部位上;所述摄像头为可旋转式摄像头。Above-mentioned camera includes the camera on the first position and/or the camera on the second position; position; the camera is a rotatable camera.
在下位机构的底部设置有一平板部,平板部既可作为清仓机器人直立的基础体,又可作为破碎仓中大煤块、导通放煤口的打击体。There is a flat plate at the bottom of the lower mechanism, and the flat plate can be used as the upright base body of the clearing robot, and can also be used as the striking body for large coal blocks in the crushing bin and leading to the coal discharge port.
在上述横向工作臂的自由端还设置有限位装置,限位装置的横向接触杆末端安装有判断是否触及仓壁触动开关。A limiting device is also arranged at the free end of the above-mentioned transverse working arm, and the end of the transverse contact rod of the limiting device is equipped with a touch switch for judging whether it touches the warehouse wall.
上述驱动机构包括防爆电动机、防爆齿轮泵及摆动液压缸,摆动液压缸配置有用于测量旋转角度的转角传感器;上述横向工作臂均配置有用于判断该臂伸缩位置的伸缩位置传感器;上述煤铲液压缸配置有用于判断该液压缸活塞杆伸缩状态的检测位置传感器。The driving mechanism includes an explosion-proof motor, an explosion-proof gear pump and a swing hydraulic cylinder. The swing hydraulic cylinder is equipped with a rotation angle sensor for measuring the rotation angle; the above-mentioned transverse working arm is equipped with a telescopic position sensor for judging the telescopic position of the arm; The cylinder is equipped with a detection position sensor for judging the telescoping state of the piston rod of the hydraulic cylinder.
上述驱动机构通过第一传动轴传动联接上位机构,通过第二传动轴传动联接下位机构;第一传动轴为纵向空心轴,第二传动轴穿经第一传动轴。The driving mechanism is connected to the upper mechanism through the first transmission shaft, and connected to the lower mechanism through the second transmission shaft; the first transmission shaft is a longitudinal hollow shaft, and the second transmission shaft passes through the first transmission shaft.
在上述上位机构与下位机构之间设置有抱紧机构,抱紧机构包括抱紧液压缸、传动连杆、刹车部,其中抱紧液压缸通过固定件体固定在上位机构中第一传动轴的下部,刹车部设置在下位机构的中央轴上部,抱紧液压缸通过传动连杆控制刹车部的动作;所述支撑臂液压缸由各自的电磁换向阀控制,其活塞腔设置单向锁和安全阀。Between the above-mentioned upper mechanism and the lower mechanism, there is a holding mechanism, which includes a holding hydraulic cylinder, a transmission connecting rod, and a brake part, wherein the holding hydraulic cylinder is fixed on the first transmission shaft of the upper mechanism through a fixing body. The lower part, the brake part is set on the upper part of the central shaft of the lower mechanism, and the hydraulic cylinder is held tightly to control the action of the brake part through the transmission link; the hydraulic cylinders of the support arm are controlled by their respective electromagnetic reversing valves, and the piston chamber is equipped with a one-way lock and safety valve.
上述井下煤仓清仓机器人配置液压泵站,液压泵站位于仓口外侧,通过进回液路与上述各机构中的液压执行装置连接,液压执行装置配置防爆电磁阀、液压锁及安全阀。The above-mentioned underground coal bunker clearing robot is equipped with a hydraulic pump station. The hydraulic pump station is located outside the warehouse mouth and is connected to the hydraulic actuators in the above-mentioned mechanisms through the inlet and return fluid lines. The hydraulic actuators are equipped with explosion-proof solenoid valves, hydraulic locks and safety valves.
本发明可通过配置相应的防爆电控系统、液压系统及卷扬装置(绞车系统)等,即能实现:在煤仓(矸石仓)轴向长度的自上而下递增靠调度绞车系统来控制;用液压站提供的液压能源来驱动进而实现上位机构的转动选位、及操控支撑臂横向伸缩对仓壁的支撑与定位,以及实现下位工作机构转动选位、工作臂横向伸缩到位及煤铲在纵向上往复运动铲切等。操作者只要在仓外通过电控系统等对井下煤仓清仓机器人进行相应操作,即可完成整个井下煤仓(矸石仓)立壁及其收缩口处的清洁任务,能够减少人力物力,实现井下清仓的机械化。The present invention can be realized by configuring the corresponding explosion-proof electric control system, hydraulic system and hoisting device (winch system), etc.: the top-to-bottom incremental increase in the axial length of the coal bunker (waste bunker) is controlled by the dispatching winch system ; Use the hydraulic energy provided by the hydraulic station to drive and realize the rotation and position selection of the upper mechanism, and the support and positioning of the warehouse wall by the lateral expansion and contraction of the control support arm, and the rotation position selection of the lower working mechanism, the horizontal expansion and contraction of the working arm and the coal shovel Reciprocating motion shoveling etc. in the longitudinal direction. The operator only needs to operate the underground coal bunker clearing robot through the electronic control system outside the warehouse, and can complete the cleaning task of the entire underground coal bunker (gangue bin) vertical wall and its shrinkage opening, which can reduce manpower and material resources and realize underground warehouse clearance. mechanization.
附图说明Description of drawings
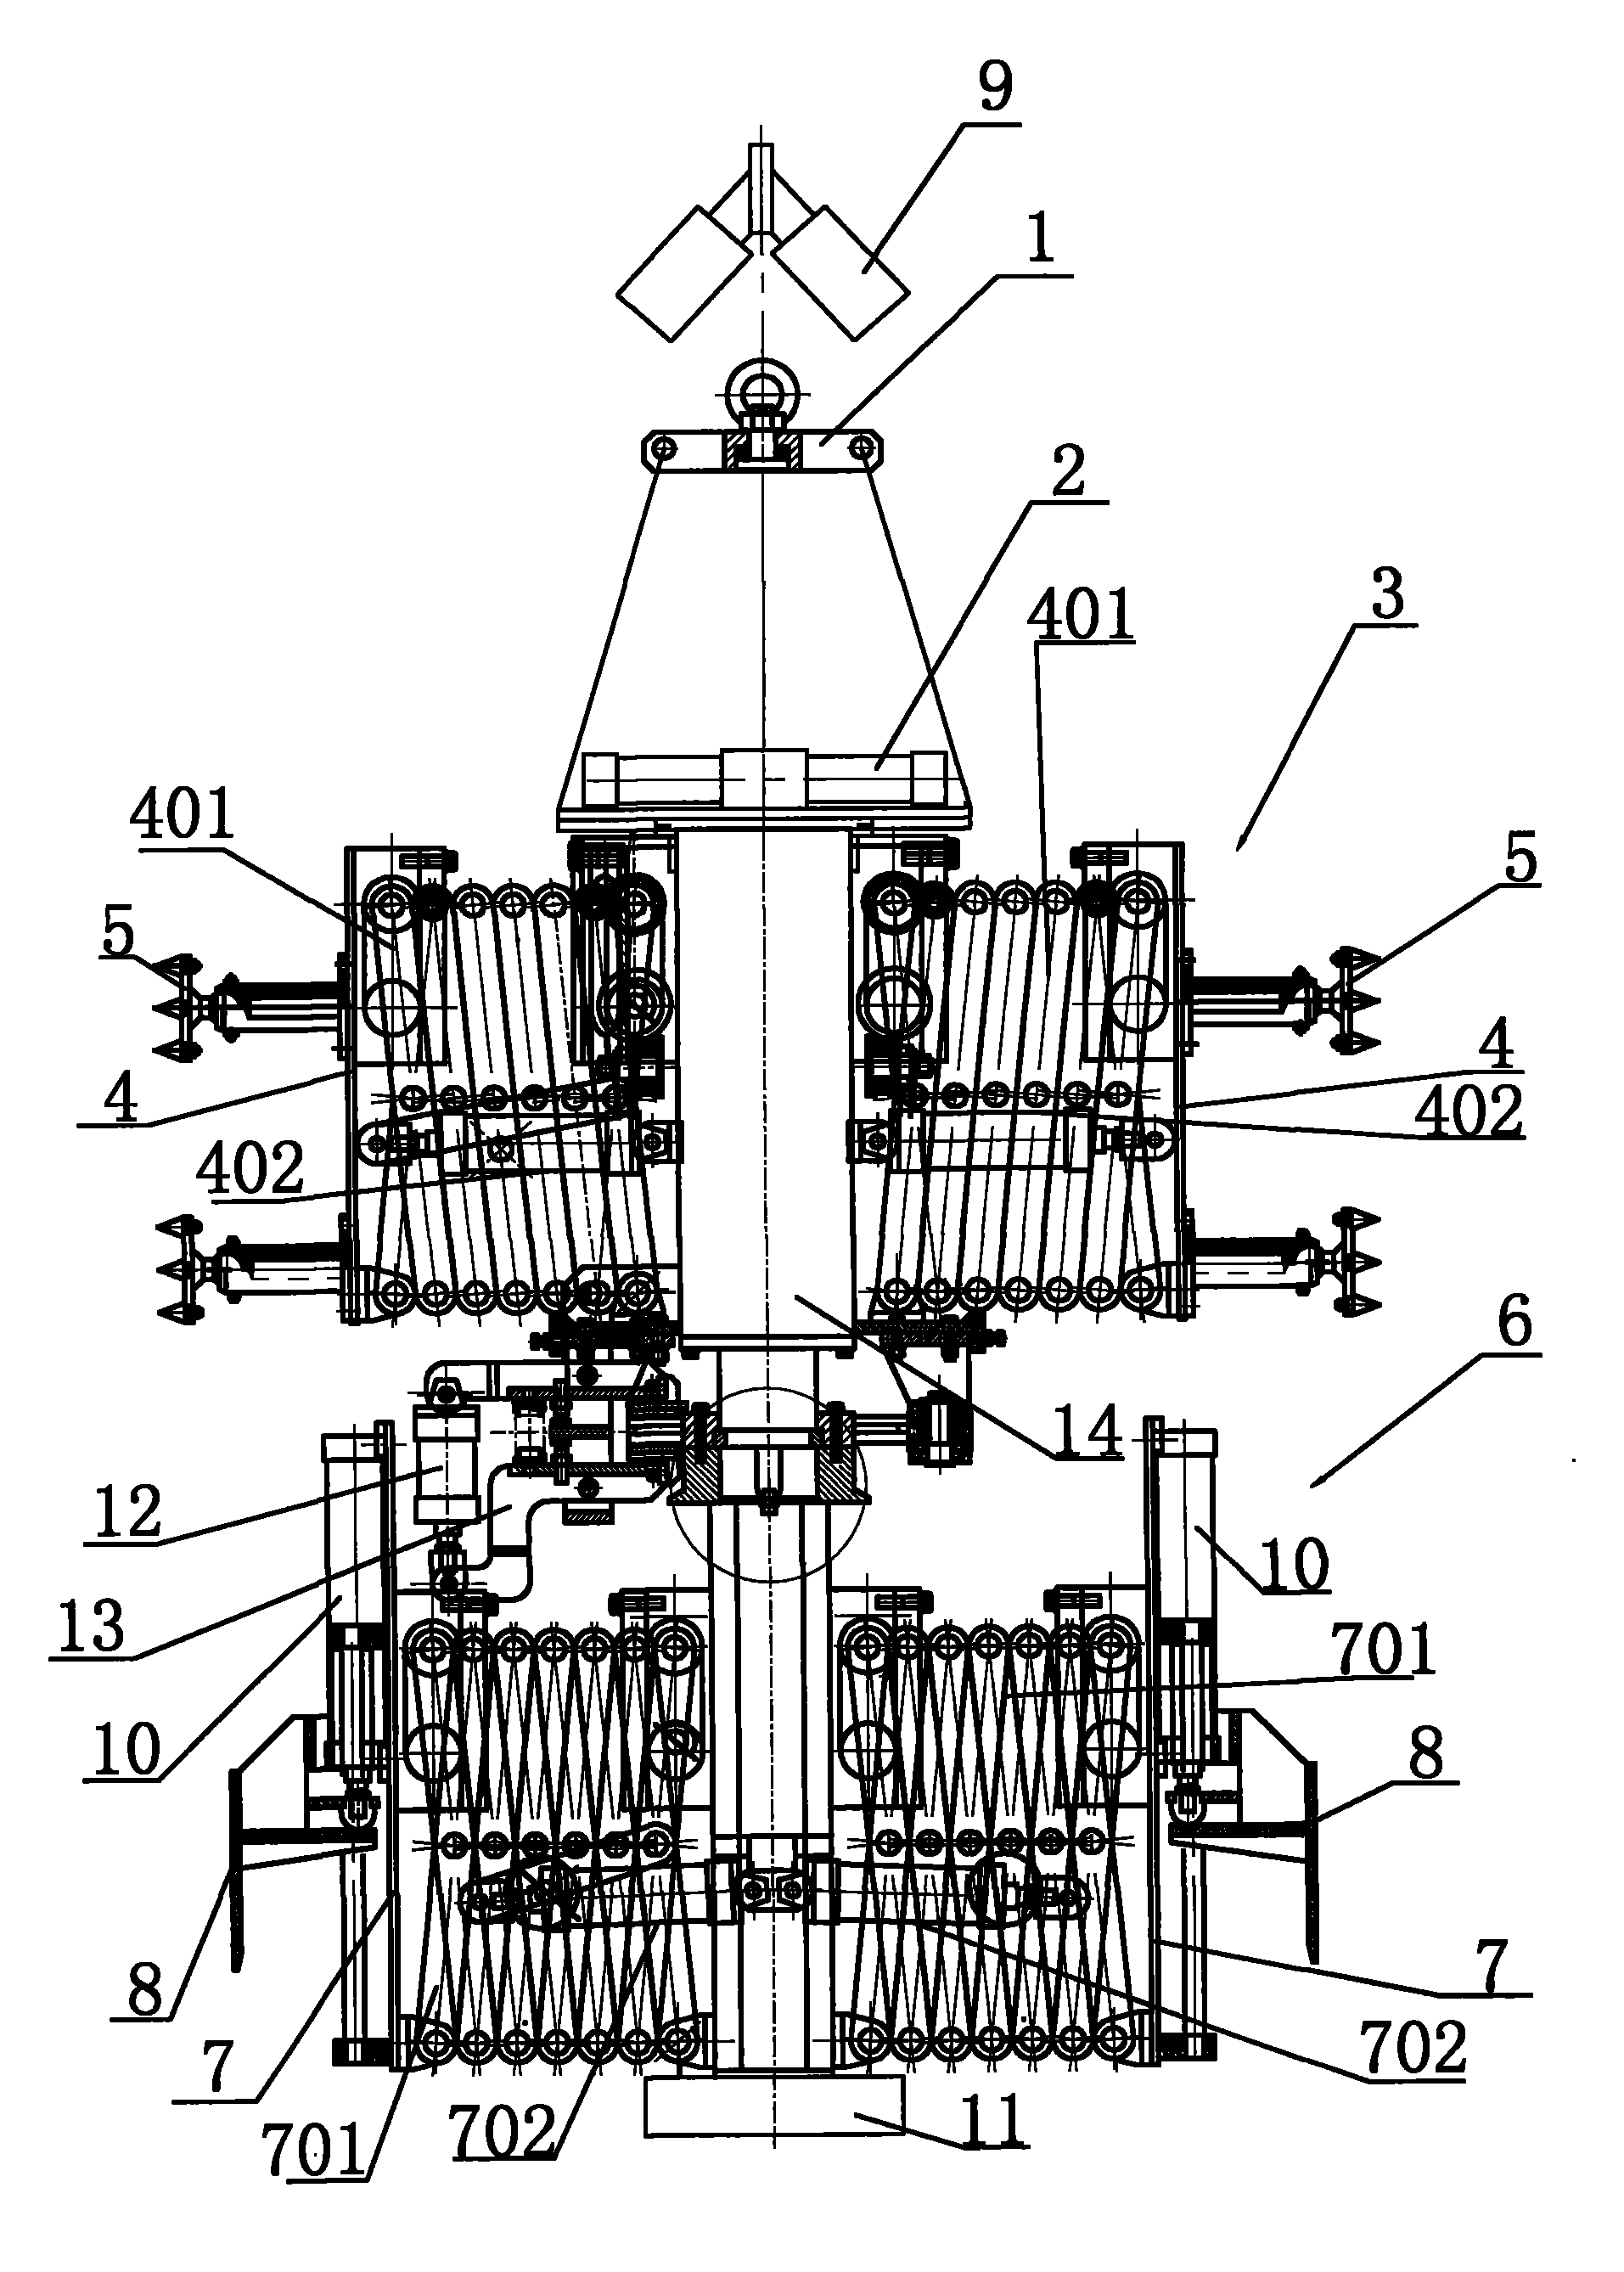
图为本发明一种实施方式结构原理示意图。The figure is a schematic diagram of the structural principle of an embodiment of the present invention.
下面结合附图对本发明进行说明:The present invention is described below in conjunction with accompanying drawing:
具体实施方式Detailed ways
结合附图,一种井下煤仓清仓机器人,包括:用于与仓外卷扬装置的牵引缆绳连接的悬吊机构1;用于驱动下述上位机构与下位机构分别旋转摆动的驱动机构2;用于支撑仓壁进行定位的上位机构3,上位机构3设置有三条能伸缩的横向支撑臂4,横向支撑臂4的自由端设置有带有尖状物的接触部5;用于铲除仓壁凝结物的下位机构6,下位机构设置有两条能伸缩的横向工作臂7,横向工作臂的自由端设置能上下往复动作的煤铲8;两只用于摄取仓壁现场情形的第二位次上的摄像头9,摄像头9与仓外监视器连接。具体说明如下:In conjunction with the accompanying drawings, an underground coal bunker clearing robot includes: a suspension mechanism 1 used to connect with the traction cable of the hoisting device outside the bunker; a drive mechanism 2 used to drive the following upper mechanism and lower mechanism to rotate and swing respectively; The upper mechanism 3 used to support the warehouse wall for positioning, the upper mechanism 3 is provided with three telescopic horizontal support arms 4, and the free end of the lateral support arms 4 is provided with a contact part 5 with a pointed object; it is used for eradicating the warehouse wall The
驱动机构2包括防爆电动机、防爆齿轮泵及摆动液压缸;驱动机构2通过第一传动轴传动联接上位机构3,通过第二传动轴传动联接下位机构6,第一传动轴为纵向空心轴,第二传动轴穿经第一传动轴。上位机构3设置有三条横向支撑臂4,三条横向支撑臂4在周向上按120°均布,每条横向支撑臂包括可伸缩支撑臂主体401及支撑臂液压缸402,支撑臂主体401采取由多节平行四边形铰接式单元组成的杆体结构,支撑臂液压缸402的活塞杆端与首节铰接式单元中的某一适宜铰杆传动连接,支撑臂液压缸402带动支撑臂主体401伸长及回缩。下位机构6设置有两条横向工作臂7,两条横向工作臂7对称布置,每条横向工作臂7包括可伸缩工作臂主体701及工作臂液压缸702,工作臂主体701采取由多节平行四边形铰接式单元组成的杆体结构,工作臂液压缸702的活塞杆端与首节铰接式单元的某一适宜铰杆传动连接,工作臂液压缸702带动工作臂主体伸长及回缩;在横向工作臂7的自由端设置有煤铲液压缸10,煤铲8固定联接在煤铲液压缸10的活塞杆端;在下位机构的底部设置有一平板部11,平板部11既可作为清仓机器人直立的基础体,又可作为破碎仓中大煤块、导通放煤口的打击体;在上述横向工作臂的自由端还设置有限位装置,限位装置的横向接触杆末端安装有判断是否触及仓壁的触动开关。在上述上位机构3与下位机构6之间设置有抱紧机构,抱紧机构包括抱紧液压缸12、传动连杆13及刹车部,其中抱紧液压缸通过固定件体固定在上位机构中第一传动轴的下部,刹车部设置在下位机构的中央轴上部,抱紧液压缸通过传动连杆控制刹车部的动作。The driving mechanism 2 includes an explosion-proof motor, an explosion-proof gear pump and a swing hydraulic cylinder; the driving mechanism 2 is connected to the upper mechanism 3 through the first transmission shaft, and connected to the
上述实施方式中,横向工作臂均可配置有用于判断该臂伸缩位置的伸缩位置传感器,煤铲液压缸配置有用于判断该液压缸活塞杆伸缩状态的检测位置传感器。上述实施方式中,支撑臂液压缸由各自的电磁换向阀控制,其活塞腔设置单向锁和安全阀;当垂吊不居中时可以调整、保护横向支撑臂和煤仓仓壁。In the above embodiments, the transverse working arm can be equipped with a telescopic position sensor for judging the telescopic position of the arm, and the coal shovel hydraulic cylinder is equipped with a detection position sensor for judging the telescopic state of the piston rod of the hydraulic cylinder. In the above embodiment, the support arm hydraulic cylinders are controlled by their respective electromagnetic reversing valves, and the piston chamber is provided with a one-way lock and a safety valve; when the suspension is not centered, the horizontal support arm and the coal bunker wall can be adjusted and protected.
上述实施方式中,上位机构3还可设置有液体介质储存箱体14,上述各有关液压缸通过相应控制管线连接液体介质储存箱体14。In the above embodiment, the upper mechanism 3 can also be provided with a liquid medium storage box 14, and the above-mentioned relevant hydraulic cylinders are connected to the liquid medium storage box 14 through corresponding control pipelines.
上述实施方式中,摄像头还包括第一位次上的摄像头,第一位次上的摄像头设置在牵引缆绳上。上述摄像头均可选用可旋转式摄像头。上述设置方式便于全方位观察清仓机器人本体和煤仓之间的相对位置。In the above embodiment, the camera further includes a camera at the first position, and the camera at the first position is arranged on the pulling cable. Above-mentioned camera all can select rotatable camera for use. The above setting method is convenient for all-round observation of the relative position between the cleaning robot body and the coal bunker.
上述实施方式中,三条横向支撑臂与两条横向工作臂等各伸缩臂均设置有断开装置。具有工作时垂直煤仓轴线,伸缩臂遇到塌方事故砸坏或液压系统故障不能完成缩回时,断开装置能使该伸缩臂绕固定轴旋转垂直放下(下垂),便于把清仓机器人本体提出仓口。In the above embodiment, each telescopic arm such as the three transverse support arms and the two transverse working arms is provided with a disconnecting device. It has a vertical axis of the coal bunker when it is working. When the telescopic arm is damaged by a landslide accident or the hydraulic system fails to retract, the disconnecting device can make the telescopic arm rotate around the fixed axis and drop down vertically (drooping), which is convenient for the robot body to be lifted out. Cangkou.
对上述各机构再进一步说明如下:A further description of the above agencies is as follows:
一、悬吊机构1. Suspension mechanism
按照人工清仓时旋梯是按照自上而下的顺序进行下放,需要一台调度绞车配合工作,井下煤仓清仓机器人一般自重为2吨左右。在煤仓正中的巷道壁上打锚杆,并在锚杆下方设置滑轮,将绞车牵引缆绳(钢丝绳)通过滑轮与悬吊机构相连后,用以实现井下煤仓清仓机器人沿煤仓轴线方向进行手动或自动的下放。According to the manual clearance, the spiral ladder is lowered in a top-down order, and a dispatching winch is required to cooperate with the work. The underground coal bunker clearance robot generally has a self-weight of about 2 tons. Bolt the bolt on the roadway wall in the middle of the coal bunker, and set a pulley under the bolt, and connect the winch traction cable (wire rope) to the suspension mechanism through the pulley to realize the underground coal bunker clearing robot along the axis of the coal bunker. Manual or automatic lowering.
遇到仓内壁面不平或有的部位出现塌陷时,井下煤仓清仓机器人可利用下位机构进行暂时支撑,上位机构横向支撑臂在支撑臂液压缸相应带动下回缩带动接触部脱离壁面,驱动上位机构旋转并脱离塌陷部位,然后上位机构横向支撑臂在支撑臂液压缸相应带动下伸展带动接触部抓牢仓壁进行支撑,下位机构可恢复到工作状态。When the inner wall of the warehouse is uneven or some parts collapse, the underground coal bunker clearance robot can use the lower mechanism for temporary support, and the horizontal support arm of the upper mechanism retracts under the corresponding drive of the hydraulic cylinder of the support arm to drive the contact part away from the wall, driving the upper The mechanism rotates and breaks away from the collapsed part, and then the horizontal support arm of the upper mechanism is stretched under the corresponding drive of the hydraulic cylinder of the support arm to drive the contact part to grasp the warehouse wall for support, and the lower mechanism can return to the working state.
二、驱动机构2. Driving mechanism
井下煤仓清仓机器人的各个运动的动力来源于仓口外的液压泵站,通过进回液路与各机构中的液压执行装置连接,液压执行装置配置防爆电磁阀、液压锁及安全阀。液压系统所使用的工作介质可选用符合井下设备使用要求的耐磨液压油。The power of each movement of the underground coal bunker clearing robot comes from the hydraulic pump station outside the bunker mouth, which is connected to the hydraulic actuators in each mechanism through the inlet and return fluid lines. The hydraulic actuators are equipped with explosion-proof solenoid valves, hydraulic locks and safety valves. The working medium used in the hydraulic system can choose wear-resistant hydraulic oil that meets the requirements of downhole equipment.
三、上位机构Third, the upper body
横向支撑臂的伸缩变化范围可选为2500mm到5000mm,在下位机构的煤铲铲除煤壁上凝结物时,上位机构能够实现可靠地支撑。当遇到煤仓壁有凹坑难以支撑时,下位机构暂停铲除动作转换为临时支撑,上位机构通过旋转选择其他适宜支撑部位,在选定的支撑部位进行可靠支撑后,下位机构恢复铲除动作。摄像头是人类眼睛功能的延伸,操作者在井口通过监视器可以判断壁上凝结物的准确位置,然后按自动/手动把凝结物铲除干净,摄像头可以绕轴旋转九十度,通过监视器也可以看清上位机构及下位机构的运行过程。三条横向支撑臂按120度均布,能够实现可靠的支撑,防止机身扭曲,影响工作稳定性。The telescopic variation range of the lateral support arm can be selected from 2500mm to 5000mm. When the coal shovel of the lower mechanism removes the condensation on the coal wall, the upper mechanism can realize reliable support. When there is a pit on the wall of the coal bunker that is difficult to support, the lower mechanism suspends the eradication action and converts it to temporary support, and the upper mechanism selects other suitable support parts through rotation. After the selected support position is reliably supported, the lower mechanism resumes the eradication action. The camera is an extension of the function of the human eye. The operator can judge the exact location of the condensate on the wall through the monitor at the wellhead, and then remove the condensate by automatic/manual. The camera can rotate 90 degrees around the axis, and the monitor can also See clearly the operation process of the upper institution and the lower institution. The three horizontal support arms are evenly distributed at 120 degrees, which can realize reliable support and prevent the fuselage from twisting and affecting the working stability.
四、下位机构4. Lower institutions
在上述上位机构到位支撑后,下位机构旋转选定铲除工位,摆动缸进出口可采用双向锁进行控制,为了更有效地防止下位机构在旋转后出现颤动影响工作机构的工作,采取抱紧机构进行协同控制。横向工作臂通过伸缩把煤铲送到铲除工位,煤铲通过煤铲液压缸实现上下往复动作用以铲除掉仓壁凝结物等。为防止下位机构撞击仓壁破坏煤铲部分,设置了限位装置,可通过控制煤铲液压缸的电磁阀断电,来保护铲煤部分。After the above-mentioned upper mechanism is in place and supported, the lower mechanism rotates to select the removal station, and the entrance and exit of the swing cylinder can be controlled by a two-way lock. In order to more effectively prevent the lower mechanism from vibrating after rotation and affecting the work of the working mechanism, a tightening mechanism is adopted. Coordinated control. The horizontal working arm sends the coal shovel to the shoveling station through telescoping, and the coal shovel reciprocates up and down through the coal shovel hydraulic cylinder to remove the condensate on the warehouse wall. In order to prevent the lower mechanism from colliding with the bin wall and damaging the coal shovel part, a limit device is set up, which can protect the coal shovel part by controlling the power-off of the solenoid valve of the coal shovel hydraulic cylinder.
本发明中,可伸缩横向支撑臂及可伸缩横向工作臂的主体可以采取现有技术中其他适宜可伸缩杆体结构等。In the present invention, the main body of the telescopic lateral support arm and the telescopic lateral working arm can adopt other suitable telescopic rod structures in the prior art.
在本说明书的教导下,本领域技术人员能够作出的显而易见的诸如替换、增加、减少等变化方式,应被认为同样落入本发明的保护范围。Under the teaching of this specification, obvious changes such as replacement, addition, reduction, etc. that can be made by those skilled in the art should be considered to also fall within the protection scope of the present invention.
Claims (9)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2009100200115A CN101526007B (en) | 2009-03-23 | 2009-03-23 | Underground coal bunker cleaning robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN2009100200115A CN101526007B (en) | 2009-03-23 | 2009-03-23 | Underground coal bunker cleaning robot |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| CN101526007A CN101526007A (en) | 2009-09-09 |
| CN101526007B true CN101526007B (en) | 2011-03-16 |
Family
ID=41094060
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN2009100200115A Expired - Fee Related CN101526007B (en) | 2009-03-23 | 2009-03-23 | Underground coal bunker cleaning robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN101526007B (en) |
Families Citing this family (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN105173445B (en) * | 2015-09-14 | 2017-10-24 | 中国矿业大学 | A kind of all-hydraulic conveyer for emptying warehouse of center steering formula and its method of work |
| CN106807655B (en) * | 2017-01-20 | 2019-04-12 | 山西戴德测控技术有限公司 | It is a kind of for clearing up bringing down stocks robot and bringing down stocks method for silo bulkhead knot ash |
| CN109129431B (en) * | 2018-10-09 | 2022-02-18 | 山东科技大学 | Large-scale coal bunker blockage cleaning robot |
| CN109747987B (en) * | 2018-12-10 | 2020-04-28 | 山东科技大学 | Clear storehouse manipulator and clear stifled robot of coal bunker |
| CN110589265A (en) * | 2019-10-30 | 2019-12-20 | 浙江量大智能科技有限公司 | Intelligent foot type walking coal bunker cleaning robot |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH073834A (en) | 1993-06-18 | 1995-01-06 | Ohbayashi Corp | Under-road excavator |
| JPH10203587A (en) | 1997-01-22 | 1998-08-04 | Ishikawajima Harima Heavy Ind Co Ltd | Coal bunker |
| CN2492542Y (en) * | 2001-07-09 | 2002-05-22 | 大屯煤电(集团)有限责任公司 | Automatic hydraulic circular warehouse clearing machine |
| CN2729014Y (en) * | 2004-09-08 | 2005-09-28 | 赵东楼 | Bulkhead emptying machine |
-
2009
- 2009-03-23 CN CN2009100200115A patent/CN101526007B/en not_active Expired - Fee Related
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH073834A (en) | 1993-06-18 | 1995-01-06 | Ohbayashi Corp | Under-road excavator |
| JPH10203587A (en) | 1997-01-22 | 1998-08-04 | Ishikawajima Harima Heavy Ind Co Ltd | Coal bunker |
| CN2492542Y (en) * | 2001-07-09 | 2002-05-22 | 大屯煤电(集团)有限责任公司 | Automatic hydraulic circular warehouse clearing machine |
| CN2729014Y (en) * | 2004-09-08 | 2005-09-28 | 赵东楼 | Bulkhead emptying machine |
Non-Patent Citations (2)
| Title |
|---|
| 巩琦.煤仓疏通技术及便携式疏通机的研究.《中国煤炭》.2008,第34卷(第8期),67-69. * |
| 张跃锋等.介休洗煤厂受煤坑四棱锥底清仓器的改进设计.《煤炭技术》.2005,第24卷(第12期),64-65. * |
Also Published As
| Publication number | Publication date |
|---|---|
| CN101526007A (en) | 2009-09-09 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN201842582U (en) | Hydraulic self-discharging crane | |
| CN105107806B (en) | Center-driven water jet bin cleaning mechanism and cleaning method thereof | |
| CN106194060B (en) | A carbon fiber continuous sucker rod operation vehicle | |
| CN101526007A (en) | Underground coal bunker cleaning robot | |
| WO2019080216A1 (en) | FULLY AUTOMATIC INDUSTRIAL ROBOT FOR STEM AND REPLACEMENT TUBE OPERATIONS | |
| CN104389532A (en) | Mechanization workover treatment system capable of replacing wellhead manual operation | |
| CN105545228A (en) | Tubular column conveying system | |
| CN105173794A (en) | Rocker arm type coal bunker cleaning machine for accumulated coal in coal bunker and cleaning method thereof | |
| CN105174022A (en) | Automatic hydraulic unhooking device | |
| WO2015158238A1 (en) | Material taking machine of steel wire rope lifting mine cart | |
| CN103662858A (en) | Dust-free loading and unloading device for bulk material | |
| CN205503141U (en) | A work platform for tunnel disease management | |
| CN105173445B (en) | A kind of all-hydraulic conveyer for emptying warehouse of center steering formula and its method of work | |
| CN110761796A (en) | Deep inclined shaft expanding excavation supporting device and construction method | |
| CN216404429U (en) | Environment-friendly bottom filter tank system for blast furnace granulated slag | |
| CN204198035U (en) | Fixing Crushing Station telescopic boom dust-arrest device | |
| CN203822204U (en) | Multilayer arrangement drill pipe box and ancillary drill pipe gate catwalk device | |
| CN201694569U (en) | A telescopic underground coal bunker wall sticky coal removal device | |
| CN207144815U (en) | A kind of CFG pile foundations are unearthed automatic recycling device | |
| CN203652827U (en) | Anti-splash device for material discharging of bunker | |
| CN111661503A (en) | Automatic cleaning device of silo | |
| CN216405532U (en) | A precise slag grabbing system for blast furnace water slag bottom filter | |
| CN109944558A (en) | A kind of automatic lifting operation platform of well-drilling oil pipe | |
| CN217627269U (en) | Multifunctional pneumatic lifting device for underground coal mine | |
| CN211033768U (en) | a warehouse system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| C06 | Publication | ||
| PB01 | Publication | ||
| C10 | Entry into substantive examination | ||
| SE01 | Entry into force of request for substantive examination | ||
| C14 | Grant of patent or utility model | ||
| GR01 | Patent grant | ||
| C17 | Cessation of patent right | ||
| CF01 | Termination of patent right due to non-payment of annual fee |
Granted publication date: 20110316 Termination date: 20120323 |